WO2025033437A1 - ロボット - Google Patents
ロボット Download PDFInfo
- Publication number
- WO2025033437A1 WO2025033437A1 PCT/JP2024/028120 JP2024028120W WO2025033437A1 WO 2025033437 A1 WO2025033437 A1 WO 2025033437A1 JP 2024028120 W JP2024028120 W JP 2024028120W WO 2025033437 A1 WO2025033437 A1 WO 2025033437A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- resin
- robot
- exterior member
- composite material
- inorganic particles
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- A—HUMAN NECESSITIES
- A63—SPORTS; GAMES; AMUSEMENTS
- A63H—TOYS, e.g. TOPS, DOLLS, HOOPS OR BUILDING BLOCKS
- A63H9/00—Special methods or compositions for the manufacture of dolls, toy animals, toy figures, or parts thereof
-
- A—HUMAN NECESSITIES
- A63—SPORTS; GAMES; AMUSEMENTS
- A63H—TOYS, e.g. TOPS, DOLLS, HOOPS OR BUILDING BLOCKS
- A63H11/00—Self-movable toy figures
Definitions
- the present invention relates to a robot.
- Robots that provide comfort to users by interacting with them have been known for some time now (see, for example, Patent Document 1).
- a robot having an exterior member that forms the outer surface, a heating element that is placed in a space surrounded by the exterior member, a heat transfer unit that transfers heat from the heating element to the exterior member, and a heat transfer control unit that adjusts the amount of heat transfer between the heating element and the exterior member by operating the heat transfer unit (see, for example, Patent Document 2).
- the exterior member be made of a soft material such as resin or rubber.
- soft materials generally have low thermal conductivity. For this reason, when a heat source such as a processor or motor is placed in a space surrounded by an exterior member made of a soft material, the heat generated by the heat source is not dissipated and the temperature in the space is likely to rise. As a result, there is a possibility that the members, mechanisms, or electronic components placed in the space surrounded by the exterior member may be damaged or malfunction.
- the present invention aims to provide a robot with a soft exterior that reduces the temperature rise in the space surrounded by the exterior material.
- a robot according to one aspect of the present invention has an exterior member and a heat source placed in a space surrounded by the exterior member, wherein the thermal conductivity of the exterior member is 0.3 W/(m ⁇ K) or more, and the compressive stress of the exterior member when compressed by 30% is 2.0 N/mm2 or less.
- the present invention can reduce the temperature rise in the space surrounded by the exterior material and provide a robot with a soft exterior.
- FIG. 1 is a schematic perspective view of a robot according to an embodiment.
- FIG. 1 is a schematic side view of a robot according to an embodiment.
- 3 is a schematic cross-sectional view taken along line III-III in FIG. 2.
- FIG. 1 is a diagram illustrating a schematic configuration of a vital sensor according to an embodiment.
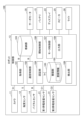
- FIG. 2 is a block diagram showing a hardware configuration of a control unit according to the embodiment.
- FIG. 2 is a block diagram showing a functional configuration of a control unit according to the embodiment.
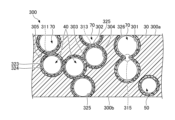
- FIG. 1 is a schematic cross-sectional view of an example of a composite material according to an embodiment.
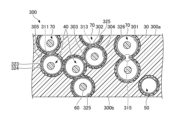
- FIG. 2 is a schematic cross-sectional view of another example of a composite material according to an embodiment.
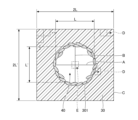
- FIG. 2 is a diagram illustrating measurement positions in a composite material of an exterior member according to an embodiment, measured by energy dispersive X-ray spectroscopy using an ultra-high resolution field emission scanning electron microscope.
- FIG. 2 is a diagram showing the results of observing a cross section of a composite material in an exterior member according to Example 1 using a scanning electron microscope.
- FIG. 13 is a diagram showing the relationship between the restoring property and the strain rate of an exterior member when a load is removed.
- the vertically upward side when the user holds the robot is referred to as "up” and the vertically downward side is referred to as "down”.
- the upward and downward directions are collectively referred to as the up-down direction.
- the direction perpendicular to the up-down direction is referred to as the horizontal direction.
- the direction in which the user is positioned when the user holds the robot is referred to as "front”
- the direction opposite to the direction in which the user is positioned is referred to as "rear”.
- the forward and rearward directions are collectively referred to as the front-rear direction.
- the direction perpendicular to the front-rear direction is referred to as the lateral direction.
- the left side as viewed from the robot according to the embodiment is referred to as the "left”
- the right side as viewed from the robot according to the embodiment is referred to as the "right”.
- terms indicating a specific direction or position e.g., “up”, “down”, “side”, “right”, “left” and other terms including these terms
- the orthogonal angle may include an error of ⁇ 10° from 90°.
- the robot according to this embodiment is a robot capable of communicating with a user.
- a user refers to a person who uses the robot. Typical examples of users include working people living alone, seniors whose children have become independent, and frail elderly people who are the recipients of home medical care. Note that users may include not only users of the robot, but also people who simply come into contact with the robot, such as the robot's administrator.
- Communication according to this embodiment includes exchange or communication using only language, and exchange or communication involving contact or interaction.
- a state in which the user touches the robot by holding the robot without speaking is also included in the state in which the user and robot are communicating with each other.
- interaction with the user refers to the act of the user and robot touching each other (act of contact), such as stroking, tapping (touching), and hugging.
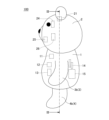
- Fig. 1 is a perspective view illustrating a robot 100 according to an embodiment.
- Fig. 2 is a side view of the robot 100.
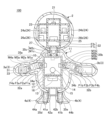
- Fig. 3 is a cross-sectional view taken along line III-III in Fig. 2.
- the robot 100 is, as an example, a doll-type robot that resembles a baby bear.
- the robot 100 can be driven by supplied power.
- the robot 100 is manufactured to have a size and weight suitable for being held by a user.
- the robot 100 is not limited to being a doll-type robot that resembles a baby bear, and may have various shapes or structures.
- the robot 100 has an exterior member 10 and a heat source disposed in a space surrounded by the exterior member 10.
- the thermal conductivity of the exterior member 10 is 0.3 W/mK or more, and the compressive stress when the exterior member 10 is compressed by 30% is 2.0 N/mm2 or less.
- the exterior member 10 may completely cover the heat source, or may have gaps or holes, or may have portions with different thicknesses.
- the exterior member 10 may be made of a uniform material, or may have portions made of different materials. When the exterior member 10 is made of multiple materials, the thermal conductivity of at least the portion of the exterior member 10 close to the heat source is 0.3 W/mK or more, and the compressive stress when the exterior member 10 is compressed by 30% is 2.0 N/mm2 or less .
- a heat source refers to any component included in the robot 100 that generates heat when driven or supplied with power.
- the camera 11, control unit 13, display 24, light 26, right arm servo motor 35a, left arm servo motor 35b, head servo motor 35c, right leg servo motor 35d, left leg servo motor 35e, etc. correspond to heat sources.
- the battery 15, which generates heat when supplied with power, also corresponds to a heat source.
- 30% compression refers to a state in which the exterior member 10 is compressed to a thickness that is 30% of the thickness of the exterior member 10 in its original, uncompressed state.
- the thickness of the exterior member 10 in its original, uncompressed state can be, for example, 10 mm or more and 50 mm or less.
- the thermal conductivity of the exterior member 10 is 0.3 W/mK or more, heat generated from a heat source arranged in a space surrounded by the exterior member 10 can be dissipated to the outside of the exterior member 10 through the exterior member 10.
- the compressive stress when the exterior member 10 is compressed by 30% is 2.0 N/ mm2 or less, a user who touches the robot 100 can feel the softness of the exterior member 10.
- the compressive stress when the exterior member 10 is compressed by 30% is preferably 1.5 N/mm2 or less , more preferably 1.0 or less.
- the exterior member 10 may be disposed away from the heat source, but from the viewpoint of heat dissipation, it is preferable that the exterior member 10 is in contact with the heat source.
- a member having a different thermal conductivity from that of the exterior member 10 may be interposed between the heat source and the exterior member 10. From the viewpoint of heat dissipation, it is preferable that a member having a higher thermal conductivity than the exterior member 10 is interposed. It is more preferable that the member having a higher thermal conductivity is exposed on the surface of the exterior member 10. It is even more preferable that the member having a higher thermal conductivity is in contact with the heat source.
- the member interposed between the heat source and the exterior member 10 may be a fluid.
- a hole serving as a flow path may be formed on the surface of the exterior member 10.
- the exterior member 10 may be in contact with the heat source at any point, and the contact point may be any one point or multiple contact points, but from the viewpoint of heat dissipation, it is preferable that there are many contact points with the heat source.
- the exterior member 10 may be in contact with the heat source on a surface, and from the viewpoint of heat dissipation, it is preferable that the contact area of the contact surface in contact with the heat source is large.
- the exterior member 10 may be further covered on the outside with a covering material.
- the covering material may have a larger surface area than the exterior member 10, or may have a smaller surface area than the exterior member 10.
- the covering material may be made of the same material as the exterior member 10, and may be formed continuously, for example, to have a film shape with fewer pores than the exterior member 10.
- a cloth material such as a raised cloth or a knitted material is preferable from the viewpoint of providing a pleasant feel.
- the specific gravity of the exterior member 10 is 1.5 or less. With the specific gravity of the exterior member 10 being 1.5 or less, the robot 100 becomes light, making it easier for the user to lift the robot 100. This promotes communication between the user and the robot 100, and can provide comfort to the user in an appropriate manner.
- a robot with a soft exterior is easily deformed by a user's touch. If the robot 100 takes a long time to return to its original state after being deformed by contact, the user may not be able to provide comfort to the user by visually recognizing the deformed robot 100. For example, a cute baby bear robot provides comfort to the user, but a baby bear robot with a deformed face or the like is less cute than a non-deformed robot, and therefore provides less comfort to the user. For this reason, it is preferable that the compression recovery speed of the robot 100, which is the speed at which the compression amount when the exterior member is compressed by 30% and then unloaded is restored to 67%, is 0.5 s -1 or more. By satisfying this condition, even if the exterior is soft and easily deformed, the time until the robot returns to its original state after deformation can be shortened. As a result, the robot 100 can maintain its cuteness and provide comfort to the user.
- the robot 100 has a torso 1, a head 2, arms 3, and legs 4.
- the head 2 has a right eye 2a, a left eye 2b, a mouth 2c, a right cheek 2d, and a left cheek 2e.
- the arms 3 include a right arm 3a and a left arm 3b, and the legs 4 include a right leg 4a and a left leg 4b.
- the torso 1 corresponds to the robot body.
- Each of the head 2, arms 3, and legs 4 corresponds to a driving body that is connected to the robot body so as to be displaceable relative to the robot body.
- the arms 3 are configured to be displaceable relative to the torso 1.
- the right arm 3a and the left arm 3b are displaced and come into contact with the user's neck, torso, etc. as if hugging the user.
- This action makes the user feel a sense of closeness to the robot 100, promoting interaction between the user and the robot 100.
- interaction with the user refers to actions in which the user and the robot 100 come into contact with each other (actions of contact), such as stroking, tapping (touching), and hugging (embracing each other).
- the torso 1, head 2, arms 3, and legs 4 are all covered with an exterior member 10.
- the exterior member on the torso 1 and the exterior member on the arms 3 are integrated, and the exterior members on the head 2 and legs 4 are separate from the exterior members on the torso 1 and arms 3.
- this is not limited to the above configuration, and for example, only the parts of the robot 100 that are likely to be touched by the user may be covered with the exterior member 10.
- at least one of the exterior members 10 on each of the torso 1, head 2, arms 3, and legs 4 may be separate from the other exterior members.
- the parts of the head 2, arms 3, and legs 4 that do not displace may not include components such as sensors inside, and may be composed only of the exterior member 10.
- a camera 11, a tactile sensor 12, a control unit 13, a vital sensor 14, a battery 15, a first capacitance sensor 21, and a second capacitance sensor 31 are arranged in a space surrounded by the exterior member 10. Also, the camera 11, the tactile sensor 12, the control unit 13, the vital sensor 14, and the battery 15 are arranged in a space surrounded by the exterior member 10 in the torso 1. Furthermore, a first capacitance sensor 21 is arranged in a space surrounded by the exterior member 10 in the head 2, and a second capacitance sensor 31 is arranged in a space surrounded by the exterior member 10 in the arm 3.
- a display 24, a speaker 25, and a light 26 are arranged in the space surrounded by the exterior member 10 in the head 2. Furthermore, a display 24 is arranged in the space surrounded by the exterior member 10 in the right eye 2a and the left eye 2b. In addition, a speaker 25 is arranged in the space surrounded by the exterior member 10 in the mouth 2c, and a light 26 is arranged in the space surrounded by the exterior member 10 in the right cheek 2d and the left cheek 2e.
- the display 24 corresponds to the display unit arranged in the eye of the robot 100.
- the speaker 25 corresponds to the sound generating unit arranged in the mouth of the robot 100.
- the light 26 corresponds to the light emitting unit arranged in the cheek of the robot 100.
- a torso frame 16 and a torso mounting platform 17 are arranged in the space surrounded by the exterior member 10 in the torso 1.
- a head frame 22 and a head mounting platform 23 are arranged in the space surrounded by the exterior member 10 in the head 2.
- a right arm frame 32a and a right arm mounting platform 33 are arranged in the space surrounded by the exterior member 10 in the right arm 3a, and a left arm frame 32b is arranged in the space surrounded by the exterior member 10 in the left arm 3b.
- a right leg frame 42a is arranged in the space surrounded by the exterior member 10 in the right leg 4a
- a left leg frame 42b is arranged in the space surrounded by the exterior member 10 in the left leg 4b.
- the torso frame 16, head frame 22, right arm frame 32a, left arm frame 32b, right leg frame 42a, and left leg frame 42b are structures formed by combining multiple columnar members.
- the torso mounting platform 17, head mounting platform 23, and right arm mounting platform 33 are plate-like members having mounting surfaces.
- the torso mounting platform 17 is fixed to the torso frame 16, the head mounting platform 23 is fixed to the head frame 22, and the right arm mounting platform 33 is fixed to the right arm frame 32a.
- the torso frame 16, head frame 22, right arm frame 32a, left arm frame 32b, right leg frame 42a, and left leg frame 42b may be formed in a box shape including multiple plate-like members.
- the right arm frame 32a is connected to the torso frame 16 via a right arm connecting mechanism 34a.
- the right arm frame 32a is driven by a right arm servo motor 35a and can be displaced relative to the torso frame 16.
- the right arm connecting mechanism 34a preferably has, for example, a reducer that increases the output torque of the right arm servo motor 35a.
- the right arm frame 32a is composed of a multi-joint robot arm including multiple frame members and multiple connecting mechanisms.
- the right arm frame 32a has a right shoulder frame F1a, a right right arm frame F2a, a right elbow frame F3a, and a right forearm frame F4a.
- the torso frame 16, right shoulder frame F1a, right right arm frame F2a, right elbow frame F3a, and right forearm frame F4a are each connected to each other via a connecting mechanism.
- Right arm servo motor 35a is a general term for multiple servo motors.
- right arm servo motor 35a has a right shoulder servo motor M1a, a right right arm servo motor M2a, a right elbow servo motor M3a, and a right forearm servo motor M4a.
- the right shoulder servo motor M1a rotates the right shoulder frame F1a around a rotation axis perpendicular to the torso frame 16.
- the right right arm servo motor M2a rotates the right right arm frame F2a around a rotation axis perpendicular to the rotation axis of the right shoulder frame F1a.
- the right elbow servo motor M3a rotates the right elbow frame F3a around a rotation axis perpendicular to the rotation axis of the right right arm frame F2a.
- the right forearm servo motor M4a rotates the right forearm frame F4a around a rotation axis perpendicular to the rotation axis of the right elbow frame F3a.
- the left arm frame 32b is connected to the torso frame 16 via a left arm connecting mechanism 34b.
- the left arm frame 32b is driven by a left arm servo motor 35b and can be displaced relative to the torso frame 16.
- the left arm 3b is displaced relative to the torso 1.
- the left arm connecting mechanism 34b preferably has, for example, a reducer that increases the output torque of the left arm servo motor 35b.
- the left arm frame 32b is composed of a multi-joint robot arm including multiple frame members and multiple connecting mechanisms.
- the left arm frame 32b has a left shoulder frame F1b, a left upper arm frame F2b, a left elbow frame F3b, and a left forearm frame F4b.
- the torso frame 16, the left shoulder frame F1b, the left upper arm frame F2b, the left elbow frame F3b, and the left forearm frame F4b are each connected to each other via a connecting mechanism.
- Left arm servo motor 35b is a general term for multiple servo motors.
- left arm servo motor 35b has a left shoulder servo motor M1b, a left upper arm servo motor M2b, a left elbow servo motor M3b, and a left forearm servo motor M4b.
- the left shoulder servo motor M1b rotates the left shoulder frame F1b around a rotation axis perpendicular to the torso frame 16.
- the left upper arm servo motor M2b rotates the left upper arm frame F2b around a rotation axis perpendicular to the rotation axis of the left shoulder frame F1b.
- the left elbow servo motor M3b rotates the left elbow frame F3b around a rotation axis perpendicular to the rotation axis of the left upper arm frame F2b.
- the left forearm servo motor M4b rotates the left forearm frame F4b around a rotation axis perpendicular to the rotation axis of the left elbow frame F3b.
- the robot 100 can achieve more realistic movements. For example, the robot 100 can move the arm 3 to "spread its hands" when a user who is feeling neutral and not doing anything is standing there, thereby inviting contact with the user. The robot 100 can also tremble its arm 3 to "be afraid” when a user is walking around feeling angry, thereby inviting contact with the user.
- the head frame 22 is connected to the torso frame 16 via a head connection mechanism 27.
- the head frame 22 is driven by a head servomotor 35c and can be displaced relative to the torso frame 16. As the head frame 22 displaces, the head 2 displaces relative to the torso 1.
- the head connection mechanism 27 preferably has, for example, a reducer that increases the output torque of the head servomotor 35c.
- the head frame 22 has a neck frame F1c and a face frame F2c.
- the torso frame 16, the neck frame F1c, and the face frame F2c are each connected to each other via a connecting mechanism.
- Head servo motor 35c is a general term for multiple servo motors.
- the head servo motor 35c has a neck servo motor M1c and a face servo motor M2c.
- the neck servo motor M1c rotates the neck frame F1c around a rotation axis perpendicular to the torso frame 16.
- the face servo motor M2c rotates the face frame F2c around a rotation axis perpendicular to the rotation axis of the neck frame F1c.
- the robot 100 can achieve more realistic movements. For example, the robot 100 can move its head 2 to "look up" at a user who is operating a mobile phone with disgust, thereby expressing concern for the user and inducing contact with the user.
- the right leg frame 42a is connected to the torso frame 16 via a right leg connecting mechanism 44a.
- the right leg frame 42a has a right leg wheel 41a on the bottom side.
- the robot 100 has two right leg wheels 41a in the front-to-rear direction of the right leg frame 42a.
- the right leg wheel 41a is driven by the right leg servo motor 35d and can rotate around a rotation axis perpendicular to the front-to-rear direction of the right leg frame 42a.
- the rotation of the right leg wheel 41a enables the robot 100 to run.
- the right leg connecting mechanism 44a preferably has a reducer that increases the output torque of the right leg servo motor 35d, for example.
- the left leg frame 42b is connected to the torso frame 16 via a left leg connecting mechanism 44b.
- the left leg frame 42b has a left leg wheel 41b on the bottom side.
- the robot 100 has two left leg wheels 41b in the front-to-rear direction of the left leg frame 42b.
- the left leg wheel 41b is driven by the left leg servo motor 35e and can rotate around a rotation axis perpendicular to the front-to-rear direction of the left leg frame 42b.
- the rotation of the left leg wheel 41b enables the robot 100 to run.
- the left leg connecting mechanism 44b preferably has a reducer that increases the output torque of the left leg servo motor 35e, for example.
- the robot 100 moves forward or backward by simultaneously rotating the right leg wheel 41a and the left leg wheel 41b forward or backward.
- the robot 100 turns right or left by braking either the right leg wheel 41a or the left leg wheel 41b and rotating the other forward or backward.
- the legs 4 allow the robot 100 to perform more realistic movements.
- the robot 100 can move the legs 4 to "approach" a user who is standing still and feeling sad or surprised, thereby enabling the robot 100 to perform an action that induces contact with the user.
- the camera 11 is fixed to the torso frame 16.
- the tactile sensor 12, the control unit 13, the vital sensor 14, and the battery 15 are fixed to the torso mounting base 17.
- the control unit 13 and the battery 15 are fixed to the torso mounting base 17 on the side opposite to the side to which the tactile sensor 12 and the vital sensor 14 are fixed.
- the arrangement of the control unit 13 and the battery 15 here is based on the available space on the torso mounting base 17 and is not necessarily limited to the above.
- the center of gravity of the robot 100 will be lowered because the battery 15 is heavier than the other components.
- a low center of gravity of the robot 100 is preferable because at least one of the position and posture of the robot 100 is stabilized and at least one of charging and replacing the battery 15 is easier to perform.
- the first capacitance sensor 21 is fixed to the head rest 23, and the second capacitance sensor 31 is fixed to the right arm rest 33.
- the display 24 has a right eye display 24a and a left eye display 24b.
- the right eye display 24a, the left eye display 24b and the speaker 25 are fixed to the head frame 22.
- the light 26 has a right cheek light 26a and a left cheek light 26b.
- the right cheek light 26a and the left cheek light 26b are fixed to the head frame 22.
- the camera 11, tactile sensor 12, control unit 13, vital sensor 14, battery 15, first capacitance sensor 21, second capacitance sensor 31, etc. can be fixed with screws or adhesive members, etc.
- the right eye display 24a, left eye display 24b, speaker 25, right cheek light 26a, left cheek light 26b, etc. can also be fixed with screws or adhesive members, etc.
- the materials used for the torso frame 16, torso mounting base 17, head frame 22, head mounting base 23, right arm frame 32a, right arm mounting base 33, and left arm frame 32b and resin or metal materials can be used.
- a metal material such as aluminum for the torso frame 16, right arm frame 32a, and left arm frame 32b.
- a resin material for these parts in order to reduce the weight of the robot 100.
- the control unit 13 is communicatively connected to each of the camera 11, tactile sensor 12, vital sensor 14, first capacitance sensor 21, second capacitance sensor 31, right arm servo motor 35a, and left arm servo motor 35b, either by wire or wirelessly.
- the control unit 13 is also communicatively connected to each of the head servo motor 35c, right leg servo motor 35d, and left leg servo motor 35e, either by wire or wirelessly.
- the control unit 13 is also communicatively connected to each of the right eye display 24a, left eye display 24b, speaker 25, right cheek light 26a, and left cheek light 26b, either by wire or wirelessly.
- the camera 11 is an image sensor that outputs captured images of the area around the robot 100 to the control unit 13. In this embodiment, the camera 11 captures an image of the user.
- the camera 11 includes a lens and an imaging element that captures an image through the lens.
- the imaging element may be a CCD (Charge Coupled Device) or a CMOS (Complementary Metal-Oxide Semiconductor), etc.
- the captured image may be either a still image or a video.
- the camera 11 is configured by a TOF (Time Of Flight) camera that outputs a distance image of the periphery of the robot 100 to the control unit 13. Therefore, the captured image output from the camera 11 may include a three-dimensional captured image (distance image) in addition to or instead of a two-dimensional captured image.
- the captured image is used to detect the presence or approach of a user, detect the distance from the robot 100 to the user, authenticate the user, or estimate the user's emotions or behavior, etc.
- the captured image corresponds to a captured image of the user.
- the robot 100 may be equipped with an ultrasonic sensor, an infrared sensor, a millimeter wave radar, or a LiDAR (Light Detection And Ranging) in addition to the camera 11.
- LiDAR Light Detection And Ranging
- the camera 11 also acquires a captured image of the user as distance information to the user, and outputs this to the control unit 13.
- the control unit 13 can, for example, acquire in advance a correspondence relationship between the image size of an object included in the captured image and the distance to the object, and obtain the distance to the user by referring to this correspondence relationship based on the size of the image of the user included in the captured image.
- the tactile sensor 12 is a sensor element that detects information sensed by the sense of touch in the human hand, etc., converts it into a tactile signal, which is an electrical signal, and outputs it to the control unit 13.
- the tactile sensor 12 corresponds to a contact detection unit that detects contact with the user.
- the tactile sensor 12 converts information about pressure and vibrations generated when the user touches the robot 100 into a tactile signal using a piezoelectric element and outputs it to the control unit 13.
- the tactile signal output from the tactile sensor 12 corresponds to contact information from the contact detection unit.
- the tactile signal is used to detect contact or presence of the user 200 with the robot 100.
- the vital sensor 14 can acquire biometric information of a movable object.
- the vital sensor 14 is an electromagnetic wave sensor that acquires biometric information of a user using electromagnetic waves.
- the vital sensor 14 will be described in detail later with reference to FIG. 4.
- the first capacitance sensor 21 and the second capacitance sensor 31 are sensor elements that detect when a user has come into contact with or near the robot 100 based on a change in capacitance and output a capacitance signal to the control unit 13.
- the first capacitance sensor 21 is preferably a rigid sensor that does not have flexibility in terms of stabilizing the exterior member 10. Since the arm 3 is a part that is easily touched by the user, the second capacitance sensor 31 is preferably a flexible sensor that includes conductive thread or the like in terms of improving the feel.
- the capacitance signals output from the first capacitance sensor 21 and the second capacitance sensor 31 are used to detect the proximity or presence of a user to the robot 100.
- the right eye display 24a and the left eye display 24b are display modules that display character strings or images such as letters, numbers, and symbols in response to commands from the control unit 13.
- the right eye display 24a and the left eye display 24b are, for example, configured with liquid crystal display modules.
- the character strings or images displayed on the right eye display 24a and the left eye display 24b are used to express the emotions of the robot 100.
- the robot 100 can implicitly induce interaction with a user by displaying a "laughing" image on the right eye display 24a and the left eye display 24b to a user who is sitting with happy emotions, thereby empathizing with the happiness.
- the speaker 25 is a speaker unit that amplifies the audio signal from the control unit 13 and outputs the sound.
- the sound output from the speaker 25 is the words or cries of the robot 100, and is used to express the emotions of the robot 100.
- the robot 100 can perform an action that induces contact with the user by outputting a "(worried) voice" sound from the speaker 25 to a user who is doing housework and feeling sad.
- the right cheek light 26a and the left cheek light 26b are light modules that blink or change color in response to an on/off signal from the control unit 13.
- the right cheek light 26a and the left cheek light 26b are, for example, configured with an LED (Light Emitting Diode) light module.
- the blinking or color change of the right cheek light 26a and the left cheek light 26b is used to express emotions of the robot 100.
- the robot 100 can express sympathy with a user who is sitting with a sad emotion by making the right cheek light 26a and the left cheek light 26b blink blue, thereby enabling the robot 100 to take an action that induces contact with the user.
- the battery 15 can supply power to the camera 11, tactile sensor 12, control unit 13, vital sensor 14, first capacitance sensor 21, second capacitance sensor 31, right arm servo motor 35a, and left arm servo motor 35b.
- the battery 15 can also supply power to the head servo motor 35c, right leg servo motor 35d, and left leg servo motor 35e.
- the battery 15 can also supply power to the right eye display 24a, left eye display 24b, speaker 25, right cheek light 26a, and left cheek light 26b.
- Various secondary batteries such as lithium ion batteries and lithium polymer batteries can be used for the battery 15.
- the various sensors in the robot 100 are not essential components.
- the robot 100 needs to have at least the camera 11, the vital sensor 14, and the tactile sensor 12.
- the installation positions of these sensors can also be changed as appropriate.
- the various sensors, such as the camera 11, the vital sensor 14, and the tactile sensor 12 may be placed outside the robot 100 and transmit necessary information to the robot 100 or an external device via wireless communication.
- the robot 100 does not necessarily have to have the control unit 13 inside the exterior member 10, and the control unit 13 can also wirelessly communicate with each device from outside the exterior member 10.
- the battery 15 can also supply power to each component from outside the exterior member 10.
- the arms 3 are configured as a four-axis articulated robot arm, but may also be configured as a six-axis articulated robot arm. It is preferable that the arms 3 are capable of connecting to an end effector such as a hand.
- the legs 4 are configured as a wheel system, but may be configured as a crawler system or a leg system, etc.
- the configuration and shape of the robot 100 are not limited to those exemplified in Figs. 1 to 3, and can be modified as appropriate according to the user's preferences and the manner in which the robot 100 is used.
- the robot 100 may be in the form of a robot arm such as an industrial robot, or in the form of a humanoid, rather than a form imitating a baby bear.
- the robot 100 may also be in the form of a mobile device such as a drone or vehicle that has at least one of an arm, a display, a speaker, and a light.
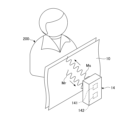
- ⁇ Configuration example of vital sensor 14> 4 is a diagram illustrating an example of the configuration of the vital sensor 14.
- the vital sensor 14 has a microwave emitting unit 141 and a microwave receiving unit 142.
- Microwaves correspond to an example of electromagnetic waves.
- the vital sensor 14 emits microwaves, ie, emitted waves Ms, from the inside of the exterior member 10 of the robot 100 toward the user 200 using the microwave emitter 141.
- the vital sensor 14 also receives reflected waves Mr, which are the emitted waves Ms reflected by the user 200, using the microwave receiver 142.
- the vital sensor 14 detects, in a non-contact manner, minute displacements occurring on the body surface of the user 200 due to factors such as the beating of the heart of the user 200, using the Doppler effect from the difference between the frequency of the emitted wave Ms and the frequency of the reflected wave Mr.
- the vital sensor 14 can obtain information on the user 200's biometric information, such as heart rate, breathing, pulse waves, and blood pressure, from the detected minute displacements, and output the obtained biometric information to the control unit 13.
- the vital sensor 14 is not limited to a microwave Doppler sensor, and may be one that detects minute displacements occurring on the body surface by utilizing changes in the coupling between the human body and an antenna, or one that utilizes electromagnetic waves other than microwaves, such as near-infrared light.
- the vital sensor 14 may also be a millimeter wave radar, microwave radar, etc.
- the vital sensor 14 also has, in addition to the Doppler sensor, a non-contact thermometer that detects infrared rays and the like emitted by the user 200. In this case, the vital sensor 14 detects the biological information of the user 200, including information regarding at least one of the heart rate (pulse), breathing, blood pressure, and body temperature.
- the vital sensor 14 is provided inside the exterior member 10, so the user 200 cannot see the vital sensor 14. This reduces the user's 200 resistance to having their biometric information detected, making it possible to acquire the biometric information smoothly.
- the vital sensor 14 can acquire biometric information without contact, it can acquire biometric information even if the user moves to a certain extent, unlike contact-type sensors that require the user to be in contact with the same place for a certain period of time.
- the vital sensor 14 can acquire biometric information when the robot 100 is being held by the user 200 and in contact with or close to the user 200.
- the vital sensor 14 can acquire highly reliable biometric information with reduced noise.
- control unit 13 is a block diagram showing a hardware configuration of the control unit 13.
- the control unit 13 is constructed by a computer and has a CPU (Central Processing Unit) 131, a ROM (Read Only Memory) 132, and a RAM (Random Access Memory) 133.
- the control unit 13 also has a HDD/SSD (Hard Disk Drive/Solid State Drive) 134, a device connection I/F (Interface) 135, and a communication I/F 136. These are connected to each other via a system bus A so as to be able to communicate with each other.
- a system bus A so as to be able to communicate with each other.
- the CPU 131 executes control processing including various types of calculation processing.
- the ROM 132 stores programs used to drive the CPU 131, such as the IPL (Initial Program Loader).
- the RAM 133 is used as a work area for the CPU 131.
- the HDD/SSD 134 stores various information such as programs, images captured by the camera 11, biological information captured by the vital sensor 14, and detection information from various sensors such as tactile signals captured by the tactile sensor 12.
- the device connection I/F 135 is an interface for connecting the control unit 13 to various external devices.
- the external devices here include the camera 11, the tactile sensor 12, the vital sensor 14, the first capacitance sensor 21, the second capacitance sensor 31, the servo motor 35, and the battery 15.
- the external devices also include the display 24, the speaker 25, and the light 26.
- servo motor 35 is a collective term for right arm servo motor 35a, left arm servo motor 35b, head servo motor 35c, right leg servo motor 35d, and left leg servo motor 35e.
- Display 24 is a collective term for right eye display 24a and left eye display 24b.
- Light 26 is a collective term for right cheek light 26a and left cheek light 26b.
- the communication I/F 136 is an interface for communicating with an external device via a communication network or the like.
- the control unit 13 connects to the Internet via the communication I/F 136 and communicates with an external device via the Internet.
- CPU 131 may be realized by electric or electronic circuits.
- Example of functional configuration 6 is a block diagram showing the functional configuration of the control unit 13.
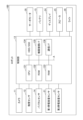
- the control unit 13 has an acquisition unit 101, a communication control unit 102, a storage unit 103, an authentication unit 104, a registration unit 105, a start control unit 106, a motor control unit 107, an output unit 108, and a detection unit 109.
- the functions of the acquisition unit 101 and the output unit 108 are realized by the device connection I/F 135, etc., and the functions of the communication control unit 102 are realized by the communication I/F 136, etc. Furthermore, the functions of the storage unit 103 and the registration unit 105 are realized by a non-volatile memory such as the HDD/SSD 134. Furthermore, the functions of the authentication unit 104, the start control unit 106, the motor control unit 107, and the detection unit 109 are realized by a processor such as the CPU 131 executing processing defined in a program stored in a non-volatile memory such as the ROM 132, etc. Note that some of the above functions may be realized by an external device such as a PC or a server, or may be realized by distributed processing between the control unit 13 and an external device.
- the acquisition unit 101 can acquire a captured image Im of the user 200 from the camera 11 by controlling communication between the control unit 13 and the camera 11.
- the acquisition unit 101 can also acquire a tactile signal S from the tactile sensor 12 by controlling communication between the control unit 13 and the tactile sensor 12.
- the acquisition unit 101 can also acquire biometric information B of the user 200 from the vital sensor 14 by controlling communication between the control unit 13 and the vital sensor 14.
- the acquisition unit 101 can acquire a first capacitance signal C1 from the first capacitance sensor 21 by controlling communication between the control unit 13 and the first capacitance sensor 21.
- the acquisition unit 101 can acquire a second capacitance signal C2 from the second capacitance sensor 31 by controlling communication between the control unit 13 and the second capacitance sensor 31.
- the communication control unit 102 can control communication with an external device via a communication network or the like.
- the communication control unit 102 can transmit the captured image Im acquired by the camera 11, the biometric information B acquired by the vital sensor 14, the tactile signal S acquired by the tactile sensor 12, etc., to the external device via the communication network.
- the storage unit 103 can store the biometric information B acquired by the vital sensor 14.
- the storage unit 103 continuously stores the acquired biometric information B while the acquisition unit 101 is acquiring the biometric information B from the vital sensor 14.
- the storage unit 103 can also store information obtained from the image Im captured by the camera 11, the tactile signal S from the tactile sensor 12, the first capacitance signal C1 from the first capacitance sensor 21, and the second capacitance signal C2 from the second capacitance sensor 31.
- the authentication unit 104 can perform personal authentication of the user 200 based on the image Im of the user 200 captured by the camera 11. For example, the authentication unit 104 performs face authentication by referring to the registration information 150 of the face image pre-registered in the registration unit 105 based on the captured image Im including the face of the user 200 captured by the camera 11. This makes it possible to associate the user 200 currently in contact with or in close proximity to the robot 100 with pre-registered personal information, and to associate the biometric information B acquired by the vital sensor 14 with the personal information. Furthermore, if the face image included in the captured image Im is not registered in the registration unit 105, the control unit 13 can control the vital sensor 14 to stop starting acquisition of biometric information.
- the start control unit 106 causes the vital sensor 14 to start acquiring biometric information B. For example, when the detection unit 109 detects that the user 200 has come into contact with or approached the robot 100, the start control unit 106 turns on a switch or the like that supplies power from the battery 15 to the vital sensor 14. This causes the start control unit 106 to cause the vital sensor 14 to start acquiring biometric information B.
- the detection unit 109 can detect the presence or approach of the user 200 around the robot 100 based on the image Im captured by the camera 11, etc.
- the detection unit 109 preferably detects the distance from the robot 100 to the user 200 based on the image Im (distance image) captured by the camera 11.
- the detection unit 109 may also detect the proximity or presence of the user 200 to the robot 100 based on the first capacitance signal C1 or the second capacitance signal C2.
- the detection unit 109 detects the contact or presence of the user 200 with the robot 100 based on the tactile signal S from the tactile sensor 12.
- the motor control unit 107 controls the driving of the servo motor 35.
- the output unit 108 controls communication between the control unit 13 and the battery 15 in response to a command from the start control unit 106.
- the output unit 108 also controls communication between the control unit 13 and the servo motor 35 in response to a command from the motor control unit 107.
- the exterior member 10 is configured to include a composite material 300.
- Fig. 7 and Fig. 8 are schematic cross-sectional views of the composite material 300 according to the embodiment.
- Fig. 7 shows an example of the composite material 300
- Fig. 8 shows another example of the composite material 300.
- Figs. 7 and 8 show a cross-section of the composite material 300 when the exterior member 10 configured to include the composite material 300 is cut along a plane approximately parallel to the thickness direction of the exterior member 10.
- the exterior member 10 has a skeleton 30 containing a first resin, a plurality of voids 40, and a plurality of inorganic particles 301.
- the composite material 300 has a heat transfer path 325 and a heat transfer path 326.
- the plurality of inorganic particles 301 form the heat transfer paths 325 and 326 that extend along the periphery of the plurality of voids 40.
- the heat transfer paths 325 and 326 are formed along the periphery of the multiple voids 40 in the composite material 300, heat in the space surrounded by the exterior member 10 is easily transferred through the composite material 300.
- the exterior member 10 can achieve a thermal conductivity of 0.3 W/(m ⁇ K) or more, and the heat dissipation property of the exterior member 10 can be improved.
- the skeleton part 30 of the composite material 300 includes a first resin
- the composite material 300 includes multiple voids 40.
- the composite material 300 can be made softer than when the skeleton part 30 does not include the first resin or when the composite material 300 does not include multiple voids 40.
- the exterior member 10 is configured to include the composite material 300, it has flexibility and is easily deformed, and therefore a compressive stress of 2.0 N/mm 2 or less can be achieved when compressed by 30%. Furthermore, the voids 40 included in the composite material 300 have excellent restoring properties to return to the original state, so that even if the composite material 300 is deformed, it can be quickly restored to almost the original state.
- the composite material 300 includes, for example, a first layer 323 and a second layer 324.
- the first layer 323 and the second layer 324 are arranged along the periphery of each of the plurality of voids 40.
- the first layer 323 includes a plurality of inorganic particles 301.
- the second layer 324 covers the first layer 323 from the side opposite to the skeleton 30 and faces the voids 40.
- the second layer 324 includes at least one resin selected from the group consisting of a first resin and a second resin different from the first resin.
- the second layer 324 may include the second resin. According to the embodiment shown in FIG.
- the first layer 323 including the plurality of inorganic particles 301 is covered by the second layer 324, so that the inorganic particles 301 are not easily peeled off from the composite material 300. As a result, the thermal conductivity performance of the composite material 300 is not easily deteriorated.
- Peeling of the inorganic particles 301 from the composite material 300 can be confirmed, for example, by the following method. After shaking the composite material 300 using a device such as a shaker, it is visually confirmed that the inorganic particles 301 have peeled off from the composite material 300. Alternatively, peeling of the inorganic particles 301 from the composite material 300 can be confirmed by shaking the composite material 300 and then performing elemental analysis on the solid matter that has peeled off from the composite material 300. For elemental analysis, methods such as inductively coupled plasma (ICP), optical emission spectroscopy, energy dispersive X-ray spectroscopy (EDX), and X-ray photoelectron spectroscopy (ESCA) are used.
- ICP inductively coupled plasma
- EDX energy dispersive X-ray spectroscopy
- ESCA X-ray photoelectron spectroscopy
- Peeling of the inorganic particles 301 from the composite material 300 can also be confirmed, for example, by checking whether the inorganic particles 301 have eluted from the composite material 300. Furthermore, elution of the inorganic particles 301 from the composite material 300 can be confirmed, for example, by the following method. After immersing the composite material 300 in a solvent such as toluene, the composite material 300 is removed from the solvent and the cloudiness of the solvent is visually confirmed. Alternatively, the solvent after immersing the composite material 300 can be volatilized and the remaining solid content is subjected to elemental analysis to confirm whether the inorganic particles 301 have eluted from the composite material 300. For elemental analysis, for example, a method such as ICP, EDX, or ESCA is used.
- the composite material 300 has a porous structure having, for example, a plurality of voids 40.
- the composite material 300 has the heat transfer path 325 and the heat transfer path 326.
- the heat transfer path 325 and the heat transfer path 326 extend, for example, in the first layer 323.
- the heat transfer path 325 and the heat transfer path 326 extend, for example, across the plurality of voids 40.
- the heat transfer path 325 and the heat transfer path 326 are formed by a plurality of inorganic particles 301 arranged continuously, in other words, in contact with or in close proximity to each other.
- the heat transfer path 325 and the heat transfer path 326 extend, for example, without passing through the inside of the skeleton 30, more specifically, along the end of the skeleton 30. For example, some of the heat transfer paths 325 reach from the surface 300a of the composite material 300 to the surface 300b opposite to the surface 300a.
- At least some of the multiple voids 40 may be arranged so that they are in contact with each other. In the composite material 300, at least some of the multiple voids 40 may be arranged so that the first layers 323 are connected to each other. For example, as shown in FIG. 7, in the composite material 300, at least some of the multiple voids 40 are arranged at the connection portion 311 so that the first layers 323 around the periphery of each void 40 are connected, but the second layers 324 are not connected.
- heat transfer path 326 does not appear to extend to surface 300b in Figure 7. However, heat transfer path 326 reaches surface 300b through inorganic particles that are not visible in this cross section. Similarly, contact between all voids cannot be confirmed in a particular cross section. For example, void 50 appears isolated in Figure 7. However, void 50 is in contact with another void adjacent to it in the thickness direction of the paper.
- connection portion 311 no inorganic particles 301 are present in the connection portion 311.
- a first layer 323 and a second layer 324 are formed in the connection portion 311. Therefore, the voids 40 that are in direct contact with each other in the connection portion 311 are not connected to each other.
- a first layer 323 and a second layer 324 are also present in the connection portion 313.
- the voids 40 that appear to be adjacent to each other across the connection portions 311 and 313 in FIG. 7 may be in direct contact and communicate with each other in a cross section other than that shown in FIG. 7.
- connection portion 315 includes a portion where the inorganic particles 301, the first layer 323, and the second layer 324 are not present.
- the voids 40 that are in contact with each other in the connection portion 315 form a single space that is connected via the connection portion 315.
- particles 60 may be present inside the voids 40.
- the particles 60 are typically resin particles.
- the particles 60 may be resin particles that have shrunk due to heat treatment.
- the resin particles before shrinkage may have a shape corresponding to the voids 40.
- the resin that occupied the voids may be removed as shown in FIG. 7, or may remain deformed as shown in FIG. 8. In the latter case, the particles 60 may be in contact with the second layer 324. Even inside the voids 50 where the presence of the particles 60 cannot be confirmed in a specific cross section, the presence of the particles 60 may be confirmed by observing another cross section.
- particles 60 smaller than the voids are present in at least a part of the voids 40 and 50.
- the inorganic particles 301 are not limited to a specific material.
- the inorganic particles 301 have, for example, a thermal conductivity higher than that of the skeleton 30.
- Examples of materials for the inorganic particles 301 are hexagonal boron nitride (h-BN), alumina, crystalline silica, amorphous silica, aluminum nitride, magnesium oxide, carbon fiber, silver, copper, aluminum, silicon carbide, graphite, zinc oxide, silicon nitride, silicon carbide, cubic boron nitride (c-BN), beryllia, diamond, carbon black, graphene, carbon nanotubes, carbon fiber, and aluminum hydroxide.
- h-BN hexagonal boron nitride
- alumina alumina
- crystalline silica amorphous silica
- aluminum nitride magnesium oxide
- carbon fiber silver, copper, aluminum, silicon carbide, graphite, zinc oxide, silicon nitride, silicon carb
- the type of inorganic particles 301 in the composite material 300 may be only one type, or two or more types of inorganic particles 301 may be combined and used in the composite material 300.
- the shape of the inorganic particles 301 is not limited to a specific shape. Examples of shapes are spherical, rod-shaped (including short fiber-shaped), scale-shaped, needle-shaped, and granular. Granular means, for example, a shape in which multiple inorganic particles 301 are aggregated using a binder, or a sintered body of multiple inorganic particles 301.
- the aspect ratio of inorganic particle 301 is not limited to a specific value.
- the aspect ratio of inorganic particle 301 may be less than 50, 40 or less, or even 30 or less.
- the aspect ratio of inorganic particle 301 may be 1 or a value greater than that, for example, 2 or more, or even 3 or more.
- the aspect ratio is determined by the ratio of the maximum diameter of a particle to the minimum diameter of the particle (maximum diameter/minimum diameter). In this specification, the minimum diameter is determined by the shortest line segment that passes through the midpoint of the line segment that determines the maximum diameter.
- the average particle size of the inorganic particles 301 is not limited to a specific value.
- the average particle size of the inorganic particles 301 is, for example, 0.05 ⁇ m to 100 ⁇ m, and may be 0.1 ⁇ m to 50 ⁇ m, 0.1 ⁇ m to 30 ⁇ m, or 0.5 to 10 ⁇ m.
- the "average particle size" can be determined, for example, by a laser diffraction scattering method.
- the average particle size is the 50% cumulative value (median diameter) d50, determined from a particle size distribution curve in which the frequency is expressed as a volume-based fraction using, for example, a particle size distribution meter (Microtrac MT3300EXII) manufactured by Microtrac Bell.
- the shape of inorganic particle 301 can be determined, for example, by observation using a scanning electron microscope (SEM) or the like. For example, if the aspect ratio (maximum diameter/minimum diameter) is 1.0 or more and less than 1.7, particularly 1.0 or more and 1.5 or less, and further 1.0 or more and 1.3 or less, and at least a portion of the outline, particularly substantially the entirety, is observed as a curve, inorganic particle 301 can be determined to be spherical.
- SEM scanning electron microscope
- the scale-like shape is a plate-like shape having a pair of main surfaces and side surfaces.
- the main surface is the surface of the inorganic particle 301 with the largest area, and is usually a substantially flat surface.
- the aspect ratio is defined as the ratio of the average dimension of the main surface to the average thickness, instead of the above definition.
- the thickness of the scale-like inorganic particle 301 means the distance between a pair of main surfaces.
- the average thickness can be obtained by measuring the thickness of any 50 inorganic particles 301 using a SEM and calculating the average value.
- the average dimension of the main surface can be the value of d50 measured using the above-mentioned particle size distribution meter.
- the aspect ratio of the scale-like inorganic particle 301 may be 1.5 or more, 1.7 or more, or even 5 or more.
- the rod-like shape is a rod-like shape such as a rod-like, columnar, dendritic, needle-like, and conical shape.
- the aspect ratio of the rod-like inorganic particle 301 may be 1.5 or more, 1.7 or more, or even 5 or more. Regardless of the shape of the inorganic particles 301, examples of the upper limit of the aspect ratio are as described above.
- the average particle size is, for example, 0.1 ⁇ m to 50.0 ⁇ m, preferably 0.1 ⁇ m to 10.0 ⁇ m, and more preferably 0.5.0 ⁇ m to 5.0 ⁇ m.
- the average dimension of the main surface of the inorganic particles 301 is, for example, 0.1 ⁇ m to 20.0 ⁇ m, and preferably 0.5 ⁇ m to 15.0 ⁇ m.
- the average thickness of the inorganic particles 301 is, for example, 0.05 ⁇ m to 1.0 ⁇ m, and preferably 0.08 ⁇ m to 0.5 ⁇ m.
- the minimum diameter (usually the short axis length) of the inorganic particles 301 is, for example, 0.01 ⁇ m to 10 ⁇ m, and preferably 0.05 ⁇ m to 1.0 ⁇ m.
- the maximum diameter (usually the long axis length) of the inorganic particles 301 is, for example, 0.1 ⁇ m or more and 20.0 ⁇ m or less, and preferably 0.5 ⁇ m or more and 10.0 ⁇ m or less. If the size of the inorganic particles 301 is in this range, the inorganic particles 301 are easily arranged along the voids 40, so that the heat transfer path 325 extending across multiple voids 40 can be reliably formed.
- the average particle size is, for example, 10.0 ⁇ m or more and 100.0 ⁇ m or less, and preferably 20.0 ⁇ m or more and 60.0 ⁇ m or less.
- the content of inorganic particles 301 in composite material 300 is not limited to a specific value.
- the content of inorganic particles 301 in composite material 300 is, for example, 10% by mass to 80% by mass, preferably 10% by mass to 70% by mass, and more preferably 10% by mass to 55% by mass.
- the content of inorganic particles 301 in composite material 300 is, for example, 1% by volume to 50% by volume, preferably 2% by volume to 45% by volume, more preferably 5% by volume to 40% by volume, and particularly preferably 5% by volume to 30% by volume.
- the content [mass %] of inorganic particles 301 in composite material 300 can be determined by removing materials other than inorganic particles 301 from composite material 300 by burning or the like. To obtain a highly accurate measurement, the content [mass %] of inorganic particles may be calculated using elemental analysis. Specifically, acid is added to composite material 300, microwaves are irradiated, and composite material 300 is subjected to pressure acid decomposition. Examples of acids that can be used include hydrofluoric acid, concentrated sulfuric acid, concentrated hydrochloric acid, and aqua regia. The solution obtained by pressure acid decomposition is subjected to elemental analysis using inductively coupled plasma atomic emission spectroscopy (ICP-AES). The content [mass %] of inorganic particles 301 can be determined based on the results.
- ICP-AES inductively coupled plasma atomic emission spectroscopy
- the content [volume %] of inorganic particles 301 in composite material 300 can be calculated from the mass and density of inorganic particles 301 contained in composite material 300 and the volume and porosity of composite material 300. Specifically, the volume A of inorganic particles 301 in composite material 300 is calculated from the mass and density of inorganic particles 301. Separately, the volume B of composite material 300 not including the volume of voids 40 is calculated based on the porosity of composite material 300. The content [volume %] of inorganic particles 301 can be calculated by (A/B) ⁇ 100. The method of calculating porosity will be described later.
- the density of the inorganic particles 301 can be determined by heating the composite material 300 at high temperature in an electric furnace to burn off the organic material, and measuring the remaining inorganic particles 301 in accordance with Japanese Industrial Standards (JIS) R 1628:1997 or JIS Z 2504:2012.
- JIS Japanese Industrial Standards
- At least a part of the inorganic particles 301 is present in the portion between the skeleton 30 and the second layer 324 in the first layer 323.
- Inorganic particles 302 and 303 which are another part of the inorganic particles 301, may be present in the connection portion 313 of the voids 40 in the first layer 323.
- inorganic particles 304 which are a part of the inorganic particles 301, may be stacked with other inorganic particles in the thickness direction of the first layer 323.
- At least a part of the inorganic particles 301 contact or are very close to adjacent inorganic particles, respectively, and constitute a part of the heat transfer path 325 and the heat transfer path 326.
- inorganic particles 305 which are another part of the inorganic particles 301, may be present surrounded by the skeleton 30.
- the skeleton 30 may contain inorganic particles 305 that are not in contact with the voids 40 inside.
- Substantially all of the inorganic particles 301 may be present in the first layer 323.
- substantially all means 90% by mass or more, further 93% by mass or more, and particularly 95% by mass or more. This configuration increases the ratio of inorganic particles that contribute to improving thermal conductivity.
- the distribution of the inorganic particles 301 inside the skeleton 30 can be measured, for example, using three-dimensional X-ray microscopy (X-ray CT).
- the first resin contained in the skeleton 30 is, for example, a cross-linked polymer.
- the first resin may be a thermosetting resin.
- thermosetting resins are phenolic resin, urea resin, melamine resin, diallyl phthalate resin, polyester resin, epoxy resin, aniline resin, silicone resin, furan resin, polyurethane resin, alkylbenzene resin, guanamine resin, xylene resin, and imide resin.
- the curing temperature of the resin is, for example, 25°C or higher and 160°C or lower.
- the first resin may be a thermoplastic resin.
- thermoplastic resins are (meth)acrylic resin, styrene resin, polyethylene terephthalate resin, polyethylene resin, polypropylene resin, polyvinyl chloride resin, acrylonitrile butadiene styrene resin, and acrylonitrile styrene resin.
- the skeleton 30, for example, does not contain inorganic particles 301, or contains inorganic particles 301 at a lower content than the first layer 323.
- the content of inorganic particles 301 in the composite material 300 can be reduced.
- a composite material 300 that can have excellent thermal conductivity performance while reducing the amount of inorganic particles 301 used can be obtained.
- the content of inorganic particles 301 contained in the skeleton 30 and the first layer 323 can be compared using a method described below, for example, scanning electron microscope/energy dispersive X-ray spectroscopy (SEM-EDX (Energy Dispersive X-ray Spectroscopy)).
- the ratio X of the ratio of atoms derived from the inorganic particles 301 to the ratio of atoms derived from the resin is calculated.
- the ratio Y of the ratio of atoms derived from the inorganic particles 301 to the ratio of atoms derived from the resin is calculated. If the relationship between X and Y satisfies X ⁇ Y, it can be determined that the content of inorganic particles 301 contained in the skeleton 30 is lower than the content of inorganic particles 301 contained in the first layer 323.
- the first layer 323 may contain at least one of the first resin and the second resin together with the inorganic particles 301.
- the second layer 324 contains at least one of the first resin and the second resin.
- the second resin may be a crosslinked polymer.
- the second resin is, for example, a thermosetting resin. Examples of thermosetting resins are as described above.
- the flow temperature of the first resin may be higher than that of the resin particles used to form the voids.
- the flow temperature of the second resin may also be higher than that of the resin particles.
- the resin particles used to form the voids may not remain in the composite material 300, but may remain in the voids 40 as shrunken particles 60.
- the flow temperature is, for example, the temperature at which the resin begins to flow out.
- the flow temperature can be analyzed, for example, by a constant rate temperature rise test using a thermal flow evaluation device (flow tester) (Shimadzu Corporation, CFT-500D (PC)).
- At least one resin selected from the group consisting of the first resin and the second resin contains a crosslinked polymer.
- the second layer 324 contains inorganic particles 301 at a lower content than the first layer 323, for example. With this configuration, the content of inorganic particles 301 in the composite material 300 can be reduced. As a result, a composite material 300 that can have excellent thermal conductivity performance while reducing the amount of inorganic particles 301 used can be obtained.
- the content of inorganic particles 301 contained in the second layer 324 and the first layer 323 can be compared using, for example, SEM-EDX, using a method described below. Specifically, the second layer 324 is analyzed using SEM-EDX to calculate the proportion P [atomic %] of atoms derived from the inorganic particles 301.
- the first layer 323 is analyzed to calculate the proportion Q [atomic %] of atoms derived from the inorganic particles 301. If P and Q satisfy the relationship P ⁇ Q, it can be determined that the content of inorganic particles 301 contained in the second layer 324 is lower than the content of inorganic particles 301 contained in the first layer 323. In the composite material 300, P and Q may satisfy the relationship P/Q ⁇ 0.3.
- the second layer 324 has an average thickness of, for example, 0.01 ⁇ m or more and 100.0 ⁇ m or less.
- the average thickness of the second layer 324 may be 0.05 ⁇ m or more and 50.0 ⁇ m or less, or 0.1 ⁇ m or more and 20.0 ⁇ m or less.
- the average thickness of the second layer 324 may be smaller than the average thickness of the first layer.
- the average thickness of the second layer 324 can be determined, for example, by observing the cross section of the composite material 300 using an SEM or the like. Specifically, the average thickness of the second layer 324 can be determined by the arithmetic average of the thicknesses of the second layer 324 at 10 randomly selected locations, or in some cases 30 locations, using an SEM. The average thickness of the first layer 323 can be determined in a similar manner. The boundaries between the first layer 323 and the skeleton 30 and the second layer 324 can be determined by regarding the layered region in which inorganic particles are present as the first layer 323, which is continuous, in other words in contact with or adjacent to each other.
- the external shape of the voids 40 and 50 may be spherical or substantially spherical.
- substantially spherical means that the ratio of the maximum diameter to the minimum diameter (maximum diameter/minimum diameter) is 1.0 to 1.5, particularly 1.0 to 1.3.
- the external shape of the voids 40 and 50 is not limited to a specific shape.
- the external shape may be rod-like or polyhedral, or may be elliptical, the ratio of which is too large to be called spherical.
- the voids 40 and 50 may be 50% or more, or even 80% or more, spherical. With foaming technology, the shape of the voids becomes irregular, so it is difficult to form voids with such a uniform shape.
- the average diameter of the voids 40 is not limited to a specific value.
- the value is, for example, 50.0 ⁇ m or more and 5000.0 ⁇ m or less, preferably 100.0 ⁇ m or more and 2000 ⁇ m or less, and more preferably 300.0 ⁇ m or more and 1500.0 ⁇ m or less.
- the "average diameter" of the voids 40 means the average diameter obtained by observing the cross section of the composite material 300 with a SEM. Specifically, the maximum and minimum diameters of any 100 voids 40 that can be observed in their entirety are measured, and the average value is taken as the diameter of each void, and the average value of the diameters of the largest 15 voids is defined as the "average diameter.”
- the ratio of the volume of the voids 40 to the volume of the composite material 300 is not limited to a specific value.
- the porosity is, for example, 10 volume % or more and 60 volume % or less, preferably 15 volume % or more and 50 volume % or less, and more preferably 20 volume % or more and 45 volume % or less.
- the porosity can be obtained by observing the cross section of the composite material 300 using an SEM, calculating the ratio of the total area of the voids 40 to the total area observed, and averaging the ratios for 10 different cross section images.
- the mass of the inorganic particles 301 contained in the composite particles is calculated from the mass of the resin particles described below and the mass of the composite particles in which the inorganic particles 301 are arranged on the surfaces of the resin particles. Separately from this, the content [mass %] of the inorganic particles 301 in the composite material 300 is calculated by inorganic element analysis.
- the mass of the inorganic particles 301 in the composite material 300 is calculated from the content [mass %] of the inorganic particles 301 and the mass of the composite material 300.
- the quantity of the composite particles used in manufacturing the composite material 300 is calculated from the mass of the inorganic particles 301 in the composite material 300 and the mass of the inorganic particles 301 contained in the composite particles.
- the volume of the voids 40 is calculated from the average diameter of the voids 40.
- the total volume of the voids 40 in the composite material 300 is calculated by multiplying the volume of the voids 40 by the number of composite particles.
- the porosity is calculated by dividing this value by the volume of the composite material 300.
- the plurality of voids 40 may have substantially similar external shapes.
- substantially similar means that 80% or more, particularly 90% or more of the voids 40 have the same geometric shape, such as a spherical shape or a regular polyhedron, based on the number of voids.
- the substantially similar external shapes of the plurality of voids 40 are preferably spherical. This external shape may be substantially spherical.
- the plurality of voids formed by foaming may also come into contact with each other as they expand individually. However, in this case, the internal pressure generated by foaming usually acts on the connection part of the voids, causing a large deformation in the vicinity of the connection part. For this reason, the foaming technique is in fact unable to form a plurality of voids that come into contact with each other and have substantially similar external shapes.
- the porous structure may have through holes extending from one main surface of the composite material 300 to the other main surface.
- the voids provided in one main surface of the composite material 300 may be connected to a space facing the other main surface of the composite material 300.
- the voids provided in one main surface of the composite material 300 may be connected to a space adjacent to a side surface intersecting with one main surface of the composite material 300.
- the main surface means the surface of the composite material 300 that has the largest area.
- the multiple voids 40 may be in contact locally. This makes it difficult for the strength of the composite material 300 to decrease even if the porosity is increased.
- the diameter of the void communication part at the connection part 315 may be 25% or less, 20% or less, or even 15% or less of the average diameter of the voids 40.
- the diameter of the communication part can be measured by SEM or X-ray CT, just like the average diameter.
- the connection parts 311 and 313 of the voids 40 are separated by the first layer 323, so there are no communication parts.
- the composite material 300 has, for example, a plurality of holes 70 on its surface.
- a plurality of holes 70 are formed on the surfaces 300a and 300b of the composite material 300.
- the average diameter of the holes 70 is, for example, 50.0 ⁇ m or more and 5000.0 ⁇ m or less. This allows the composite material 300 and the user to have a desired contact area. As a result, the exterior member 10 has flexibility, and the user who comes into contact with the exterior member 10 can feel the softness of the exterior member 10.
- the average diameter of the holes 70 is preferably 100.0 ⁇ m or more and 2000.0 ⁇ m or less, more preferably 300.0 ⁇ m or more and 1500.0 ⁇ m or less.
- the "average diameter" of the holes 70 means the average diameter obtained by observing the surface of the composite material 300 with an optical microscope. Specifically, the maximum and minimum diameters of any 100 holes 70 that can be observed in their entirety are measured, and the average value is taken as the particle size of each hole, and the average value of the particle sizes of the 100 holes is defined as the "average diameter". However, depending on the size of the holes 70, the average diameter may be measured using a SEM instead of an optical microscope. The average diameter of the holes 70 may also be the average diameter of the resin particles described below.
- the maximum and minimum diameters of any 100 resin particles that can be observed in their entirety with an optical microscope are measured, and the average value is taken as the particle size of each resin particle, and the average value of the particle sizes of the 100 resin particles is defined as the "average diameter".
- the composite material 300 may be a non-foamed material.
- Conventional foamed materials cannot have the characteristic structure shown in Figures 7 and 8, i.e., a structure in which the arrangement of inorganic particles 301 is finely and precisely controlled.
- conventional foamed materials cannot have a structure in which a second layer is formed to cover a first layer containing inorganic particles.
- the following is an example of a method for determining the measurement positions for determining the composition of each element in the first layer 323, the second layer 324, and the skeleton 30 in the composite material 300 of the exterior member 10.
- the voids 40 are observed by SEM for the composite material 300.
- the longest diameter of the voids 40 observed by SEM is measured, and a line segment A having the length L of this longest diameter is determined.
- a line segment B is determined that passes through the midpoint of the line segment A, is perpendicular to the line segment A, and has a length L' from one end of the void 40 to the other end.
- a rectangle C is determined with the midpoint of the line segment A as its center of gravity, and has two adjacent sides that are parallel to the line segment A and the line segment B, respectively, and have a length twice that of the parallel line segment A or B (2L in the direction parallel to the line segment A, and 2L' in the direction parallel to the line segment B).
- the area of this rectangle C excluding the void portion is defined as the measurement area.
- This measurement area is divided into multiple regions D, each defined by a 50 ⁇ m square. The proportion of atoms contained in each of the multiple regions D is analyzed. For example, energy dispersive X-ray spectroscopy in an ultra-high resolution field emission scanning electron microscope is used for the analysis.
- the region where the ratio [atomic %] of atoms (e.g., B) contained in the inorganic particles is the largest is defined as the measurement position of the composition of the first layer 323.
- the region where the ratio [atomic %] of atoms (e.g., B) contained in the inorganic particles is the smallest is defined as the measurement position of the composition of the skeleton 30.
- the intersection point of the line segment A and the line segment B is defined as the center of gravity, and the region defined by a square of 50 ⁇ m on each side is defined as region E.
- the atom to be analyzed may be an element of the positive ion of the compound when the inorganic particles are composed of a compound, and may be an element constituting the simple substance when the inorganic particles are composed of a simple substance.
- the inorganic particles are boron nitride (BN)
- the atom to be analyzed is boron (B).
- the inorganic particles are alumina (Al 2 O 3 )
- the atom to be analyzed is aluminum (Al).
- the atom to be analyzed is carbon (C).
- the composite material 300 has a thermal conductivity of, for example, 0.3 W/(m ⁇ K) or more.
- the thermal conductivity of the composite material 300 is more preferably 0.5 W/(m ⁇ K) or more.
- the upper limit of the thermal conductivity is not limited to a specific value. The value may be, for example, 2.5 W/(m ⁇ K), 2.2 W/(m ⁇ K), or 2.0 W/(m ⁇ K).
- the thermal conductivity of the composite material 300 is a value measured using one test specimen and a symmetrical construction method in accordance with, for example, the American Society for Testing and Materials (ASTM) standard D5470-01.
- the stress when the composite material 300 is compressed by 30% is, for example, 2.0 N/ mm2 or less.
- the stress when the composite material 300 is compressed by 30% is preferably 1.0 N/ mm2 or less, more preferably 0.5 N/mm2 or less, even more preferably less than 0.2334 N/ mm2 , and particularly preferably 0.1 N/mm2 or less .
- the lower limit of the stress when the composite material 300 is compressed by 30% may be 0.05 N/ mm2 or 0.08 N/ mm2 .
- the stress when the composite material 300 is compressed by 30% can be obtained, for example, in accordance with JIS K 7181:2011.
- EZ-test "EZ-S" manufactured by Shimadzu Corporation can be used for measuring the stress when the composite material 300 is compressed by 30%.
- the composite material 300 includes a skeleton 30 containing a first resin and a plurality of voids 40.
- the method for producing the composite material 300 includes, in this order, a step of filling a fluid containing a first resin or a precursor of the first resin into voids of a particle assembly containing a plurality of resin particles, and a step of forming a plurality of voids 40 by heating the plurality of resin particles to shrink or remove them.
- a first layer 323 and a second layer 324 are present on the surfaces of the plurality of resin particles.
- the first layer 323 and the second layer 324 are arranged such that the second layer 324 is interposed between the surface of the resin particle and the first layer 323, and the surface of the resin particle and the second layer 324 are in contact with each other.
- the first layer 323 also includes a plurality of inorganic particles.
- the second layer 324 includes at least one resin selected from the group consisting of the first resin and a second resin different from the first resin.
- the at least one resin selected from the group consisting of the first resin and the second resin may include a crosslinked polymer.
- the flow temperature of the first resin, and in the case where the second layer 324 contains a second resin, the flow temperature of the second resin may be higher than the flow temperature of the resin constituting the resin particles.
- the adhesive contains, for example, at least one of a first resin and a second resin.
- the adhesive may contain a precursor of at least one of the first resin and the second resin.
- inorganic particles 301 are added to this mixture and mixed to obtain composite particles in which inorganic particles 301 are arranged on the surfaces of multiple resin particles.
- the step of adding an additive to resin particles to obtain a mixture and the step of adding inorganic particles 301 to this mixture may be repeated multiple times.
- the additive and inorganic particles 301 may be simultaneously added to a mixture of resin particles and additive, and mixed to obtain composite particles.
- the mixing method is not limited to a specific method.
- mixing methods include mixing using a ball mill, a bead mill, a planetary mixer, an ultrasonic mixer, a homogenizer, a planetary mixer, a rotation-revolution mixer, a fluid mixer, a Henschel mixer, a container rotation type blender, a ribbon blender, and a conical screw blender.
- the composite particles are placed inside a mold so that the composite particles come into contact with one another to form a particle aggregate.
- a separately prepared fluid is further added to this mold to prepare a mixture.
- the fluid contains a first resin.
- the fluid may contain a precursor of the first resin.
- the fluid is filled into the voids of the particle aggregate containing the multiple resin particles.
- the fluid is present at least on the surfaces of the composite particles and in the contact areas between the composite particles. In this way, an aggregate of multiple composite particles is formed in which at least a portion of the multiple composite particles come into contact with one another such that the heat transfer path formed by the inorganic particles 301 in contact with one another extends via the surfaces of the multiple composite particles.
- air bubbles are removed from the mixture.
- the method for removing air bubbles from the mixture is not limited to a specific method.
- An example of such a method is vacuum degassing. Vacuum degassing is performed, for example, at a temperature of 25°C or higher and 200°C or lower for 1 to 10 seconds.
- the mixture is heated to reduce the fluidity of the fluid.
- heating the fluid for example, a reaction occurs in which the first resin is produced from the precursor of the first resin, or the hardening of the first resin progresses, reducing the fluidity of the fluid.
- a skeleton 30 containing the first resin is produced. This results in a precursor of the composite material.
- the resin particles are shrunk or removed from the composite material precursor to produce the composite material 300.
- the method for shrinking or removing the resin particles from the composite material precursor is not limited to a specific method. Examples of the method include a method of heating the composite material precursor and a method of immersing the composite material precursor in a specific solvent. These methods may be used in combination. As a result, the voids 40 are formed. In this way, the composite material 300 having the skeleton 30, the first layer 323, and the second layer 324 can be obtained.
- the composite material 300 may be prepared as follows. First, a composite particle is prepared in which an adhesive and inorganic particles 301 are arranged on the surfaces of a plurality of resin particles. The method for preparing the composite particle is as described above. Next, the prepared composite particle is heated to reduce the fluidity of the adhesive arranged on the surface of the composite particle. When the adhesive is heated, for example, a reaction proceeds in which at least one of the precursors of the first resin and the second resin is produced from at least one of the precursors of the first resin and the second resin, or the hardening of at least one of the first resin and the second resin proceeds, thereby reducing the fluidity of the adhesive. In this way, a composite particle material is produced that includes the first layer and the second layer on the surface of the resin particle and also includes inorganic particles 301.
- the composite particulate material with voids formed therein is placed inside a mold.
- a separately prepared fluid is then added to the mold to prepare a mixture.
- the method for preparing the mixture is as described above.
- the mixture is heated to reduce the fluidity of the fluid.
- the method for reducing the fluidity of the fluid is as described above. In this manner, a composite material 300 having a skeleton 30, a first layer 323, and a second layer 324 can be obtained.
- the second layer 324 is formed from the resin or its precursor interposed between the surface of the resin particle and the inorganic particle 301.
- the resin may be the first resin, i.e., the resin contained in the skeleton 30, or the second resin, i.e., a resin different from this resin.
- a crosslinked polymer in which crosslinking progresses is suitable as the resin or its precursor.
- the second layer 324 is not formed when polyethylene glycol, which is a non-crosslinkable polymer, is used.
- An example of such a method is a method in which only the second layer 324 containing the resin or its precursor is first formed on the entire surface of the resin particle, and then the first layer 323 is formed.
- the temperature to which the composite material precursor is heated is not limited to a specific temperature, so long as it is a temperature that can soften the resin particles.
- the temperature may be, for example, 95°C or higher and 130°C or lower, or 120°C or higher and 160°C or lower.
- the flow temperature of the additive is higher than the flow temperature of the resin particles, for example. Therefore, even if the composite material precursor is heated to soften the resin particles, the additive is less likely to flow. As a result, the second layer 324 is more likely to be formed so as to cover the first layer 323 containing the inorganic particles 301.
- the solvent is not limited to a specific solvent as long as it does not dissolve the first resin or the second resin and can dissolve the resin particles.
- the solvent are toluene, ethyl acetate, methyl ethyl ketone, and acetone.
- the resin particles may have a hollow structure.
- the hollow portion in the hollow structure may be a single hollow portion, or may be composed of multiple hollow portions like expanded resin beads.
- the resin constituting the resin particles is softened by heat treatment, the hollow portion disappears or shrinks, and multiple voids 40 are formed accordingly.
- the hollow structure of the resin particles is not essential.
- the resin particles dissolve in the solvent more easily than, for example, the first resin or the second resin. According to such a method, voids 40 having a desired shape are easily formed.
- the resin particles are, for example, polystyrene (PS), polyethylene (PE), polymethyl methacrylate (PMMA), ethylene vinyl acetate copolymer (EVA), polyethylene (PE), polyvinyl chloride (PVC), polypropylene (PP), acrylonitrile butadiene styrene copolymer (ABS), ethylene propylene diene rubber (EPDM), thermoplastic elastomer (TPE), and polyvinyl alcohol (PVA).
- PS polystyrene
- PE polyethylene
- PMMA polymethyl methacrylate
- EVA ethylene vinyl acetate copolymer
- PE polyethylene
- PVC polyvinyl chloride
- PP polypropylene
- EPDM acrylonitrile butadiene styrene copolymer
- TPE thermoplastic elastomer
- PVA polyvinyl alcohol
- the first resin is, for example, the resin contained in the skeleton 30.
- the resin particles are not limited to a particular size.
- their average diameter is, for example, 50.0 ⁇ m to 5000.0 ⁇ m, preferably 300.0 ⁇ m to 2000.0 ⁇ m, and particularly 500.0 ⁇ m to 1500.0 ⁇ m.
- the composite material 300 can have an appropriate porosity.
- the composite material 300 can have an appropriate void size.
- the resin particles may use resins of multiple sizes selected from these sizes. In other words, the resin particles may have external shapes that are substantially similar to each other. This allows the composite material 300 to have multiple voids 40 that have external shapes that are substantially similar to each other.
- the manufacturing method of the composite material 300 according to this embodiment can form a first layer 323 containing inorganic particles 301 and a second layer 324 that covers the first layer 323 from the side opposite the skeleton 30 and faces the voids 40.
- a heat transfer path extending across multiple voids 40 can be formed by the inorganic particles 301.
- the voids 40 are formed inside the first resin without going through a foaming process. In other words, the voids 40 are not formed by foaming.
- the reaction solution was raised to 120°C over 30 minutes. Then, the reaction solution was kept at 120°C for 1 hour to prepare a styrene resin particle-containing solution. After cooling the styrene resin particle-containing solution to 95°C, 2 parts by weight of cyclohexane and 7 parts by weight of butane were pressed into the autoclave as a blowing agent. Then, the solution was raised to 120°C again. After that, the solution was kept at 120°C for 1 hour, and then cooled to room temperature to obtain a polymerization slurry. The polymerization slurry was dehydrated, washed, and dried to obtain expandable styrene resin particles.
- the expandable styrene resin particles were sieved to obtain expandable styrene resin particles having a particle diameter of 0.2 mm to 0.3 mm.
- the expandable styrene resin particles were used in a pressure expansion machine (BHP) manufactured by Daikai Kogyo Co., Ltd. to obtain spherical expandable polystyrene beads having an average diameter of 650.0 ⁇ m to 1200.0 ⁇ m.
- the expandable polystyrene beads were sieved through JIS test sieves having nominal openings (JIS Z 8801-1:2019) of 1.18 mm and 1.0 mm.
- the expandable polystyrene beads that passed through the sieve with a nominal opening of 1.18 mm and did not pass through the sieve with a nominal opening of 1.0 mm were used in the subsequent tests.
- the bulk density of the expanded polystyrene beads was 0.025 g/cm 3 .
- Example 1 As an adhesive, a silicone resin precursor was prepared by mixing the A and B components of DOWSIL SE 1896 FR A/B manufactured by Dow in a weight ratio of 1:1. 7.5 parts by weight of this silicone resin precursor was prepared per 1 part by weight of expanded polystyrene beads. Separately, a filler mixture was prepared by mixing 13.3 parts by weight of flaky boron nitride (aspect ratio 20) and 1.3 parts by weight of graphite (aspect ratio 12) per 1 part by weight of expanded polystyrene beads.
- Thermosetting resin was made by mixing Dow's DOWSIL SE 1817 CV M agent A and agent B with silicone oil (KF-96-300CS) in a weight ratio of 37.5:37.5:25.
- thermosetting resin used was Dow's DOWSIL SE 1817 CV M, agent A and agent B, and silicone oil (KF-96-300CS).
- the thermosetting resin was made by mixing agent A, agent B, and silicone oil in a weight ratio of 37.5:37.5:25.
- the aforementioned boron nitride and graphite coated polystyrene beads were packed into a plastic case with an inner diameter of 95 mm x 95 mm x 24 mm, and a plain woven wire mesh (diameter: 0.18 mm, 50 mesh) manufactured by Yoshida Takashi Stainless Steel Co., Ltd. was laid inside the plastic case, and a stainless steel punched metal (diameter: 5 mm, thickness: 1 mm, pitch: 8 mm) was laid on top of that and fixed in place with clamps.
- thermosetting resin was added to this plastic case and degassed under reduced pressure.
- the pressure at this time was -0.08 MPa to -0.09 MPa in gauge pressure.
- This operation was repeated three times to impregnate the thermosetting resin between the polystyrene beads.
- the silicone resin was cured by heating at 80°C for two hours, and a resin molded product containing polystyrene beads was obtained.
- This resin molded product was cut to the specified dimensions. It was immersed in acetone for 30 minutes to dissolve the polystyrene beads and allow them to flow out of the resin molded product.
- the resin molded product was then heated at 90°C to volatilize the acetone, producing a composite material that constitutes the exterior member of Example 1.
- Example 2 A composite material was obtained in the same manner as in Example 1, except that alumina particles (CB-P05) (spherical, aspect ratio 1) manufactured by Showa Denko K.K. were used as the inorganic particles instead of scaly boron nitride (aspect ratio 20) and graphite (aspect ratio 12), and 50 parts by weight of the inorganic particles were mixed with 1 part by weight of expanded polystyrene beads to prepare a filler mixture.
- alumina particles CB-P05
- spherical, aspect ratio 1 manufactured by Showa Denko K.K.
- Example 3 The exterior member according to Example 3 was made of Hypersoft (6550H) acrylic polymer manufactured by 3M.
- Example 4 The exterior member used in Example 4 was made of silicone rubber (K-125) manufactured by Togawa Rubber Co., Ltd.
- Comparative Example 1 The exterior member according to Comparative Example 1 was made of aluminum alloy A5052.
- Comparative Example 2 The exterior member according to Comparative Example 2 was made of soft urethane foam.
- Comparative Example 3 As the exterior member according to Comparative Example 3, one made of EPT SEALER (No. 6800) manufactured by Nitto Denko Corporation was used.
- Comparative Example 4 The exterior member according to Comparative Example 4 was made of chloropropylene rubber.
- Figure 10 shows the results of observing the cross section of the composite material 300 in the exterior member 10 of Example 1 with a scanning electron microscope.
- a void 40 is formed in the skeleton 30, and a first layer 323 containing inorganic particles and a second layer 324 covering the first layer 323 from the void 40 side are arranged along the periphery of the void 40.
- a single resin material is used in Examples 1 and 2, it is also possible to use different resins for the adhesive and the skeleton, and to configure the skeleton and the second layer to contain different resins.
- the thickness of the silicone grease layer was 100 ⁇ m.
- an upper rod having a heating block (80° C.) and a lower rod having a cooling block (20° C.) were used.
- an oxygen-free copper block was used.
- a measurement sample was prepared by sandwiching the test piece between the oxygen-free copper blocks via a silicone grease layer. The test sample was sandwiched between the upper and lower rods, and heat was allowed to flow in the thickness direction of the test piece.
- the temperature difference ⁇ T S between the upper and lower surfaces of the test piece was determined according to the following formulas (1) and (2).
- ⁇ T C is the temperature difference between the upper surface of the upper layer and the lower surface of the lower layer of the oxygen-free copper block (test block).
- q 1 is the heat flux [W/m 2 ] determined by the temperature gradient calculated based on the temperature difference at multiple temperature measurement points of the upper rod
- q 2 is the heat flux [W/m 2 ] determined by the temperature gradient calculated based on the temperature difference at multiple temperature measurement points of the lower rod.
- t b is the sum of the thicknesses of the oxygen-free copper block.
- k b is the thermal conductivity of the oxygen-free copper block.
- the thermal conductivity ⁇ 1 [W/(m ⁇ K)] in the thickness direction of the test piece was determined according to the following formula (3).
- the stress was measured when pressure was applied by an indenter to the exterior members according to Examples 1 to 4 and each of Examples 1 to 4 to compress them by 30%.
- the pressure E compressing stress [N/mm 2 ] was measured after compressing the main surface of an exterior member having a thickness of 3 mm and an area of the main surface of 10 mm ⁇ 10 mm by 30% in the thickness direction at a pressing speed of 0.5 mm/min.
- the main surface of the exterior member means the surface of the exterior member to which pressure is applied by an indenter.
- the pressure E (compressive stress) [N/mm 2 ] was measured after compressing the main surface of a composite material having a thickness of 5 mm and an area of 10 mm ⁇ 10 mm by 30% in the thickness direction at a pressing speed of 0.5 mm/min.
- the indenter used in the small tabletop testing machine EZ-test had a diameter of 25 mm.
- the item to be evaluated for the restorability of the object is the compression recovery speed, which is the speed at which the compression amount when the exterior member 10 is compressed by 30% and then unloaded returns to 67%.
- the compression recovery speed is assumed to be approximately equal to the strain rate, and the restorability of each object when unloaded is evaluated by measuring the strain rate.
- the strain rate is the value obtained by dividing the speed at which the indenter rises with the restoration of the object when unloaded from a compressed state by the thickness of the object in an uncompressed state.
- the object be restored to a thickness of at least 1/2 of the thickness of the object in the original uncompressed state immediately after unloading, and it is even more preferable that the object be restored to a thickness of at least 2/3 (67%) of the thickness of the object in the original state.
- Figure 11 is a diagram showing an example of the relationship between the restorability of the exterior member 10 when unloaded and the strain rate.
- the strain rate was measured using a small benchtop testing machine EZ-test "EZ-S" manufactured by Shimadzu Corporation.
- the horizontal axis of Figure 11 represents the position of the indenter in the small benchtop testing machine EZ-test, and the vertical axis represents the measured stress value obtained from the small benchtop testing machine EZ-test.
- Position P0 represents the position of the indenter before it comes into contact with the object and applies pressure, i.e., the original position of the object's surface.
- Position P1 represents the position of the indenter at 30% compression.
- Position P2 represents the position of the indenter when the stress measurement becomes nearly zero when the indenter is moved away from the object's surface (positive direction on the horizontal axis) from the 30% compressed state and the load is removed. In other words, position P2 represents the position of the indenter when the displacement of the object's surface accompanying the restoration does not keep up with the movement of the indenter, and the indenter moves away from the object's surface and enters a non-contact state.
- Graphs G1 and G2 show the relationship between the position of the indenter and the stress.
- Graphs G1 and G2 show different speeds of movement of the indenter from the surface of the compressed object.
- Graph G1 shows the case where the indenter is moved at a slow speed
- graph G2 shows the case where the indenter is moved at a faster speed than that of graph G1.
- the stress becomes nearly zero at an earlier timing than that of graph G1, and the restoration of the object cannot keep up with the movement of the indenter.
- the measured value of the strain rate was the indenter movement speed at which the thickness of the object when the stress becomes nearly zero due to the movement of the indenter is restored to 67% or more of its original thickness.
- the specific gravity of each of the exterior members of Examples 1 to 4 and Comparative Examples 1 to 4 was calculated by calculating the density of the exterior member from the dimensions (thickness of the exterior member ⁇ area of the main surface) measured with a dial gauge and the mass measured with an electronic balance, and then calculating the specific gravity as a value relative to the density of water (1.0 g/cm3).
- Table 1 shows the measurement results of thermal conductivity, compressive stress, strain rate, and specific gravity, as well as the evaluation results of heat dissipation, softness, and restorability for each of Examples 1 to 4 and Comparative Examples 1 to 4.
- “ ⁇ ” indicates good, and “ ⁇ ” indicates not good.
- “-" in the measurement results indicates that it cannot be measured, and “-" in the evaluation results indicates that it cannot be evaluated.
- Examples 1 and 2 obtained good results in terms of heat dissipation, softness, and restorability.
- Examples 3 and 4 obtained good results in terms of heat dissipation and softness, but poor results in restorability.
- Comparative Example 1 being made of metal, has high thermal conductivity and good heat dissipation, but poor results in terms of softness. Furthermore, since metal hardly deforms in the first place, the restorability of Comparative Example 1 could not be evaluated.
- Comparative Examples 2 to 4 obtained poor results in terms of heat dissipation.
- Table 2 shows the results of a more detailed evaluation of the restorability of each of Examples 1 to 4 and Comparative Examples 1 to 4.
- Table 2 shows the evaluation results of the restoration rate for each strain rate in each of Examples 1 to 4 and Comparative Examples 1 to 4.
- the restoration rate refers to the ratio of the thickness of an object restored when unloaded from a compressed state to its original thickness. The larger the percentage value shown in Table 2, the closer the thickness has been restored to the original thickness.
- Example 1 the thickness was restored to 67% or more at any strain rate. Therefore, it can be seen that Examples 1 and 2 have high restorability.
- Example 3 the thickness was not restored to 67% or more at any strain rate
- Example 4 when the strain rate was 0.05 S -1 , the thickness was not restored to 67% or more.
- Comparative Example 1 is a metal, so as described above, it does not deform in the first place.
- Comparative Examples 2 to 4 the thickness was restored to 67% or more at any strain rate. Therefore, it can be seen that Comparative Examples 2 to 4 have high restorability.
- the robot according to this embodiment is not easily broken due to its soft exterior and reduced temperature rise in the space surrounded by the exterior material, so it is particularly suitable for use in promoting oxytocin secretion and providing healing (a sense of security or self-affirmation) to working people living alone, seniors whose children have become independent, frail elderly people receiving home medical care, etc.
- the robot is not limited to this use, and can be used for providing healing to a variety of users.
- aspects of the present invention are as follows.
- a robot having an exterior member and a heat source arranged in a space surrounded by the exterior member, wherein the thermal conductivity of the exterior member is 0.3 W/(m ⁇ K) or more, and a compressive stress when the exterior member is compressed by 30% is 2.0 N/mm2 or less .
- a compression recovery speed which is a speed at which the exterior member recovers to 67% of the compressed amount when a load is removed after the exterior member is compressed by 30%, is 0.5 s ⁇ 1 or more.
- ⁇ 4> The robot according to any one of ⁇ 1> to ⁇ 3>, wherein the exterior member is composed of a composite material, the composite material having a skeletal portion including a first resin, a plurality of voids, and a plurality of inorganic particles, the plurality of inorganic particles forming heat transfer paths extending along peripheries of the plurality of voids.
- ⁇ 5> The robot described in ⁇ 4>, wherein the composite material has a first layer and a second layer arranged along a periphery of each of the plurality of voids, the first layer contains the plurality of inorganic particles, and the second layer contains at least one type of resin selected from the group consisting of the first resin and a second resin different from the first resin, and covers the first layer from the side opposite the skeletal portion and faces the voids.
- ⁇ 6> The robot according to ⁇ 4> or ⁇ 5>, wherein the composite material has a plurality of holes on a surface thereof, and an average diameter of the holes is 50.0 ⁇ m or more and 5000.0 ⁇ m or less.
Landscapes
- Manipulator (AREA)
- Toys (AREA)
Abstract
Description
図1~図3を参照して、実施形態に係るロボットの構成について説明する。図1は、実施形態に係るロボット100を例示する斜視図である。図2は、ロボット100の側面図である。図3は、図2におけるIII-III線の断面図である。
図4は、バイタルセンサ14の構成を例示する図である。バイタルセンサ14は、マイクロ波発射部141と、マイクロ波受信部142と、有する。マイクロ波は電磁波の一例に対応する。
(ハードウェア構成例)
図5は、制御部13のハードウェア構成を示すブロック図である。制御部13は、コンピュータによって構築されており、CPU(Central Processing Unit)131と、ROM(Read Only Memory)132と、RAM(Random Access Memory)133と、を有する。また制御部13は、HDD/SSD(Hard Disk Drive/Solid State Drive)134と、機器接続I/F(Interface)135と、通信I/F136と、を有する。これらは、システムバスAを介して相互に通信可能に接続している。
図6は、制御部13の機能構成を示すブロック図である。制御部13は、取得部101と、通信制御部102と、格納部103と、認証部104と、登録部105と、開始制御部106と、モータ制御部107と、出力部108と、検出部109と、を有する。
ロボット100では、外装部材10は、複合材料300を含んで構成される。図7及び図8は、実施形態に係る複合材料300の模式的断面図である。図7は複合材料300の一例を示し、図8は複合材料300の別の一例を示している。図7及び図8は、複合材料300を含んで構成される外装部材10を、外装部材10の厚み方向と略平行な平面により切断したときの複合材料300の断面を示している。
以下に、複合材料300の製造方法の一例について説明する。複合材料300は、第1樹脂を含む骨格部30と複数の空隙40とを含む。複合材料300の製造方法は、複数の樹脂粒子を含む粒子集合体の空隙に第1樹脂又は第1樹脂の前駆体を含む流動体を充填する工程と、複数の樹脂粒子を加熱して収縮又は除去することにより、複数の空隙40を形成する工程と、をこの順に具備する。ここで、複数の樹脂粒子の表面には第1層323及び第2層324が存在する。第1層323及び第2層324は、樹脂粒子の表面と第1層323との間に第2層324が介在し、かつ樹脂粒子の表面と第2層324とが接するように配置される。また、第1層323は、複数の無機粒子を含む。第2層324は、第1樹脂及び第1樹脂とは異なる第2樹脂からなる群より選択される少なくとも1種の樹脂を含む。第1樹脂及び第2樹脂からなる群より選択される少なくとも1種の樹脂は、架橋ポリマーを含んでいてもよい。第1樹脂の流動温度、及び第2層324が第2樹脂を含む場合は第2樹脂の流動温度は、樹脂粒子を構成する樹脂の流動温度より高くてもよい。
実施例により、本発明をより詳細に説明する。なお、本発明は以下の実施例に何ら限定されない。
純水100重量部、リン酸三カルシウム0.2重量部、及びドデシルベンゼンスルホン酸ナトリウム0.01重量部を、撹拌機が付属されているオートクレーブに加えた。このオートクレーブに、開始剤としてベンゾイルパーオキサイド0.15重量部及び1,1-ビス(t-ブチルパーオキシ)シクロヘキサン0.25重量部を加えて混合液を作製した。混合液を350回転/分で撹拌しながら、スチレンモノマー100重量部を加えた。その後、この溶液を98℃まで昇温させることによって重合反応を実施した。重合反応が約80%終了したとき、反応溶液を30分間かけて120℃まで昇温させた。その後、反応溶液を120℃で1時間保温して、スチレン樹脂粒子含有溶液を作製した。スチレン樹脂粒子含有溶液を95℃まで冷却した後、発泡剤としてシクロヘキサン2重量部及びブタン7重量部をオートクレーブに圧入した。その後、この溶液を再度120℃まで昇温させた。その後、溶液を120℃で1時間保温した後、室温まで冷却することによって、重合スラリーを得た。この重合スラリーを脱水、洗浄、及び乾燥させることによって、発泡性スチレン樹脂粒子を得た。この発泡性スチレン樹脂粒子をふるいにかけて、粒子径が0.2mm以上0.3mm以下の発泡性スチレン樹脂粒子を得た。この発泡性スチレン樹脂粒子を、大開工業社製の加圧式発泡機(BHP)を用いて、650.0μm以上1200.0μm以下の平均径を有する球形状の発泡ポリスチレンビーズを得た。この発泡ポリスチレンビーズを、公称目開き(JIS Z 8801-1:2019)が1.18mm及び1.0mmであるJIS試験用ふるいにかけた。このとき、公称目開きが1.18mmのふるいを通過し、かつ、公称目開きが1.0mmのふるいを通過しなかった発泡ポリスチレンビーズを以後の試験に使用した。なお、この発泡ポリスチレンビーズの嵩密度は、0.025g/cm3であった。
添着剤として、ダウ社製のDOWSIL SE 1896 FR A/BのA剤及びB剤を1:1の重量比で混合して、シリコーン樹脂前駆体を調製した。このシリコーン樹脂前駆体を、発泡ポリスチレンビーズ1重量部に対して7.5重量部準備した。これとは別に、発泡ポリスチレンビーズ1重量部に対して、鱗片状の窒化ホウ素(アスペクト比20)13.3重量部とグラファイト(アスペクト比12)1.3重量部とを混合してフィラー混合物を準備した。
無機粒子として、鱗片状の窒化ホウ素(アスペクト比20)とグラファイト(アスペクト比12)の代わりに、昭和電工社製のアルミナ粒子(CB-P05)(球状、アスペクト比1)無機粒子を使用し、発泡ポリスチレンビーズ1重量部に対して、50重量部となるように混合してフィラー混合物を準備したことを除き、実施例1と同様にして複合材料を得た。
実施例3に係る外装部材として、3M社製ハイパーソフト(6550H)アクリルポリマーにより構成されるものを使用した。
実施例4に係る外装部材として、十川ゴム社製シリコーンゴム(K-125)により構成されるものを使用した。
比較例1に係る外装部材として、アルミ合金 A5052により構成されるものを使用した。
比較例2に係る外装部材として、軟質ウレタンフォームにより構成されるものを使用した。
比較例3に係る外装部材として、日東電工社製エプトシーラー(No6800)により構成されるものを使用した。
比較例4に係る外装部材として、クロロプロピレンゴムにより構成されるものを使用した。
米国材料試験協会規格(ASTM)D5470-01(一方向熱流定常法)に準拠して、レスカ社製の熱伝導率測定装置TCM1001を用いて、試験体1枚及び対称構成方式にて熱流計法により実施例1及び実施例2に係る複合材料並びに比較例1~比較例4に係る複合材料の熱伝導率を測定した。具体的に、まず、厚さt=4000μmの複合材料を20mm×20mmの大きさに切断し、試験片を得た。試験片の主面の両面に、サンハヤト社製のシリコーングリース(SHC-20、熱伝導率:0.84W/(m・K))を、シリコーングリース層の厚さが100μmになるように塗布した。標準ロッドとして、加熱ブロック(80℃)を有する上部ロッド及び冷却ブロック(20℃)を有する下部ロッドを使用した。試験ブロックとして、無酸素銅製のブロックを使用した。試験片を、シリコーングリース層を介して無酸素銅製のブロックで挟んで測定試料を作製した。この測定試料を、上部ロッドと下部ロッドとの間に挟んだ。試験片の厚み方向に熱を流した。
qS=(q1+q2)/2 ・・・ 式(2)
島津製作所社製の小型卓上試験機EZ-test「EZ-S」を用いて、実施例1~実施例4、並びに実施例1~実施例4のそれぞれに係る外装部材に対して、圧子により圧力を加えて30%圧縮させたときの応力を測定した。具体的には、実施例1及び実施例2では、厚さ3mm、主面の面積10mm×10mmの外装部材の主面を、押し込み速度0.5mm/minで厚み方向に30%圧縮させたあとに測定される圧力E(圧縮応力)[N/mm2]を測定した。なお、外装部材の主面は、圧子により圧力が加えられる外装部材の面を意味する。実施例3、実施例4、並びに比較例1~比較例4では、厚さ5mm、面積10mm×10mmの複合材料の主面を、押し込み速度0.5mm/minで厚み方向に30%圧縮させたあとに測定される圧力E(圧縮応力)[N/mm2]を測定した。小型卓上試験機EZ-testにおける圧子には直径が25mmのものを用いた。
実施例1~実施例4、並びに比較例1~比較例4のそれぞれに係る外装部材の復元性を評価するために、本明細書に示す例では、該外装部材における除荷時の歪み速度を測定した。
実施例1~実施例4、並びに比較例1~比較例4のそれぞれに係る外装部材の比重は、ダイヤルゲージにて測定した寸法(外装部材の厚さ×主面の面積)と、電子天秤にて測定した質量とから外装部材の密度を算出し、水の密度(1.0g/cm3)に対する値として算出した。
表1に、実施例1~4、並びに比較例1-4それぞれの、熱伝導率、圧縮応力、歪み速度及び比重の測定結果と、放熱性、柔らかさ及び復元性の評価結果と、を示す。なお、評価結果において、「〇」は良好であること、「×」は良好でないこと、をそれぞれ表している。また、測定結果における「-」は測定できないことを表し、評価結果における「-」は、評価できないことを表している。

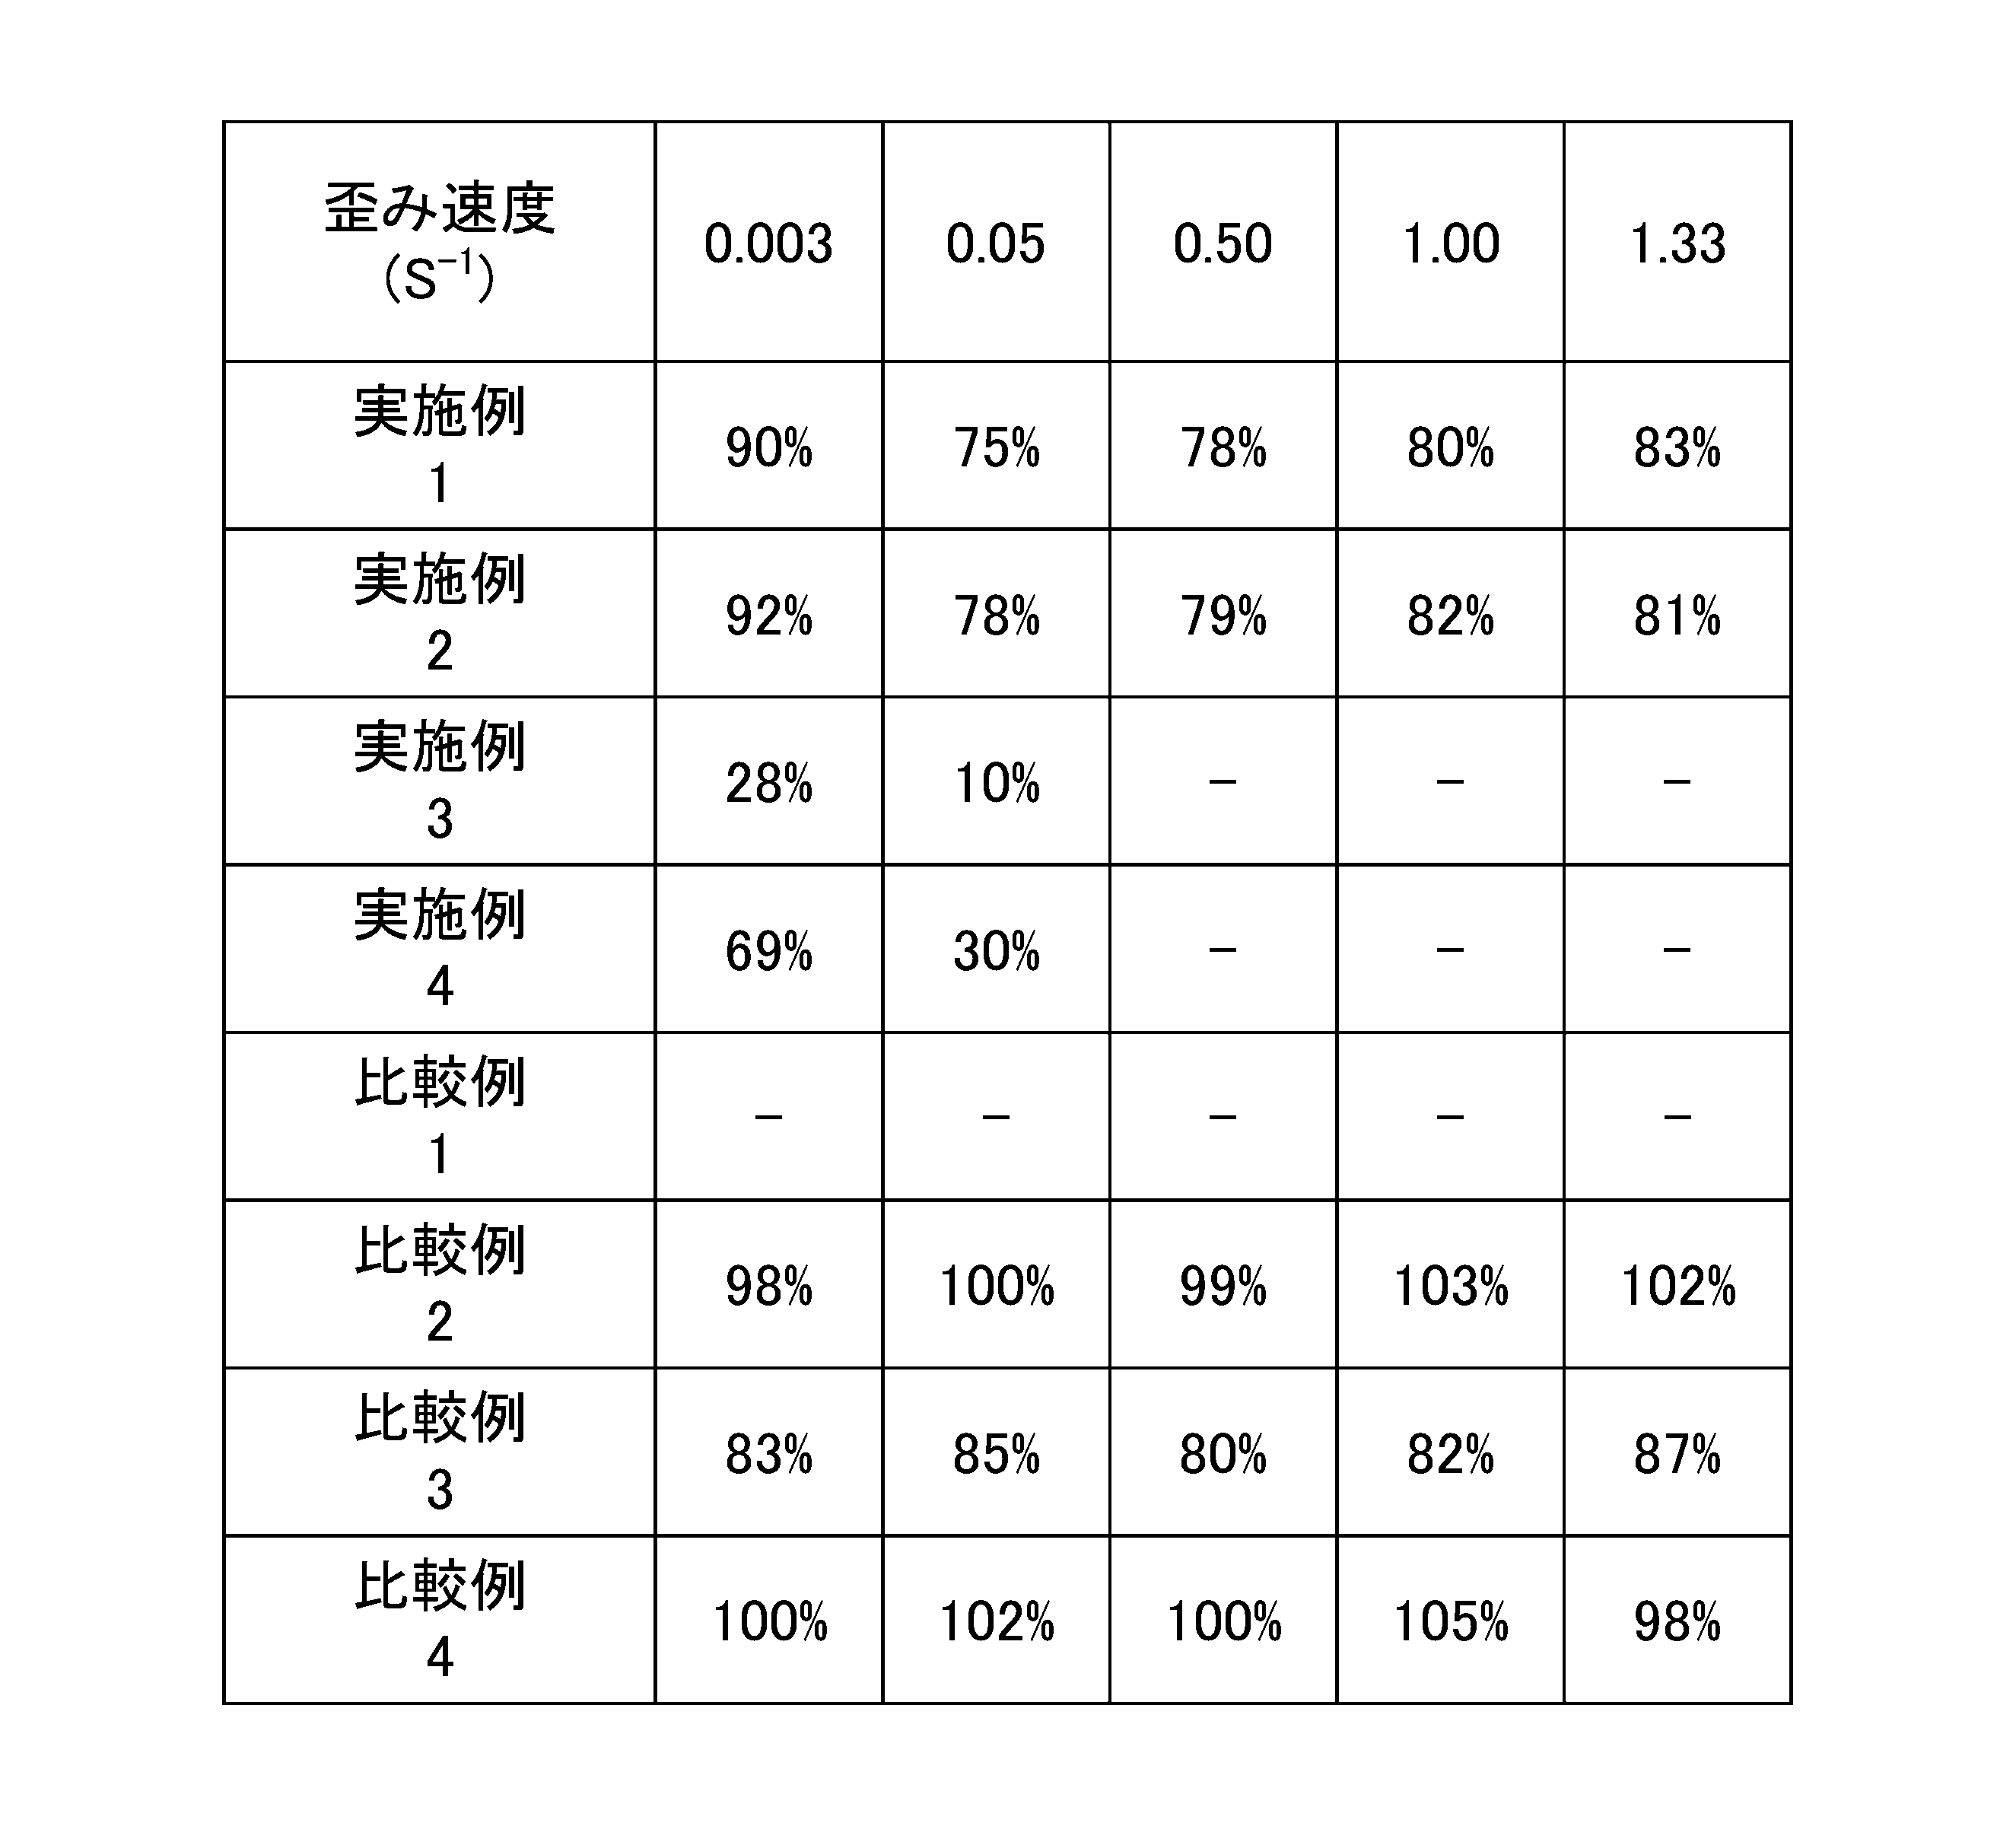
<1> 外装部材と、前記外装部材により囲まれる空間に配置される熱源と、を有し、前記外装部材の熱伝導率は、0.3W/(m・K)以上であり、前記外装部材が30%圧縮したときの圧縮応力は、2.0N/mm2以下である、ロボットである。
<2> 前記外装部材の比重は、1.5以下である、前記<1>に記載のロボットである。
<3> 前記外装部材が30%圧縮した後、除荷したときの圧縮量が67%まで復元する速度である圧縮回復速度は、0.5s-1以上である 前記<1>又は前記<2>に記載のロボットである。
<4> 前記外装部材は、複合材料を含んで構成され、前記複合材料は、第1樹脂を含む骨格部と、複数の空隙と、複数の無機粒子と、を有し、前記複数の無機粒子は、前記複数の空隙の周縁に沿って延びる伝熱路をなしている、前記<1>から前記<3>のいずれか1つに記載のロボットである。
<5> 前記複合材料は、前記複数の空隙それぞれの周縁に沿って配置された第1層及び第2層を有し、前記第1層は、前記複数の無機粒子を含み、前記第2層は、前記第1樹脂及び前記第1樹脂とは異なる第2樹脂からなる群より選択される少なくとも1種の樹脂を含み、かつ、前記骨格部と反対側から前記第1層を覆うと共に前記空隙に面する、前記<4>に記載のロボットである。
<6> 前記複合材料は、複数の孔を表面に有し、前記孔の平均径は、50.0μm以上5000.0μm以下である、前記<4>又は前記<5>に記載のロボットである。
2 頭部
2a 右眼部
2b 左眼部
2c 口部
2d 右頬部
2e 左頬部
3 腕部
3a 右腕部
3b 左腕部
4 脚部
4a 右脚部
4b 左脚部
10 外装部材
11 カメラ
12 触覚センサ
13 制御部
14 バイタルセンサ
141 マイクロ波発射部
142 マイクロ波受信部
15 バッテリ
16 胴部フレーム
17 胴部載置台
21 第1静電容量センサ
22 頭部フレーム
23 頭部載置台
24 ディスプレイ
241 白目部
242 瞳部
243 ハイライト部
24a 右眼ディスプレイ
24b 左眼ディスプレイ
25 スピーカ
26 ライト
26a 右頬ライト
26b 左頬ライト
27 頭部連結機構
31 第2静電容量センサ
32a 右腕部フレーム
32b 左腕部フレーム
33 右腕部載置台
34a 右腕部連結機構
34b 左腕部連結機構
35 サーボモータ
35a 右腕部サーボモータ
35b 左腕部サーボモータ
35c 頭部サーボモータ
35d 右脚部サーボモータ
35e 左脚部サーボモータ
41a 右脚部車輪
41b 左脚部車輪
42a 右脚部フレーム
42b 左脚部フレーム
44a 右脚部連結機構
44b 左脚部連結機構
100 ロボット
101 取得部
102 通信制御部
103 格納部
104 認証部
105 登録部
106 開始制御部
107 モータ制御部
108 出力部
109 検出部
131 CPU
132 ROM
133 RAM
134 HDD/SSD
135 機器接続I/F
136 通信I/F
200 ユーザ
201 撮影用光源
30 骨格部
40、50 空隙
60 粒子
70 孔
300 複合材料
300a、300b 表面
301~305 無機粒子
311、313、315 接続部
323 第1層
324 第2層
325、326 伝熱路
A システムバス
B 生体情報
C1 第1静電容量信号
C2 第2静電容量信号
F1a 右肩部フレーム
F2a 右上腕部フレーム
F3a 右肘部フレーム
F4a 右前腕部フレーム
F1b 左肩部フレーム
F2b 左上腕部フレーム
F3b 左肘部フレーム
F4b 左前腕部フレーム
F1c 頸部フレーム
F2c 顔部フレーム
Im 撮影画像
L 照射光
Ms 発射波
Mr 反射波
M1a 右肩部サーボモータ
M2a 右上腕部サーボモータ
M3a 右肘部サーボモータ
M4a 右前腕部サーボモータ
M1b 左肩部サーボモータ
M2b 左上腕部サーボモータ
M3b 左肘部サーボモータ
M4b 左前腕部サーボモータ
M1c 頸部サーボモータ
M2c 顔部サーボモータ
Im 撮影画像
S 触覚信号
Claims (6)
- 外装部材と、
前記外装部材により囲まれる空間に配置される熱源と、を有し、
前記外装部材の熱伝導率は、0.3W/(m・K)以上であり、
前記外装部材が30%圧縮したときの圧縮応力は、2.0N/mm2以下である、ロボット。 - 前記外装部材の比重は、1.5以下である、請求項1に記載のロボット。
- 前記外装部材が30%圧縮した後、除荷したときの圧縮量が67%まで復元する速度である圧縮回復速度は、0.5s-1以上である 請求項1又は請求項2に記載のロボット。
- 前記外装部材は、複合材料を含んで構成され、
前記複合材料は、第1樹脂を含む骨格部と、複数の空隙と、複数の無機粒子と、を有し、
前記複数の無機粒子は、前記複数の空隙の周縁に沿って延びる伝熱路をなしている、請求項1又は請求項2に記載のロボット。 - 前記複合材料は、前記複数の空隙それぞれの周縁に沿って配置された第1層及び第2層を有し、
前記第1層は、前記複数の無機粒子を含み、
前記第2層は、前記第1樹脂及び前記第1樹脂とは異なる第2樹脂からなる群より選択される少なくとも1種の樹脂を含み、かつ、前記骨格部と反対側から前記第1層を覆うと共に前記空隙に面する、請求項4に記載のロボット。 - 前記複合材料は、複数の孔を表面に有し、
前記孔の平均径は、50.0μm以上5000.0μm以下である、請求項4に記載のロボット。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2025539540A JPWO2025033437A1 (ja) | 2023-08-09 | 2024-08-06 | |
| KR1020267005377A KR20260066707A (ko) | 2023-08-09 | 2024-08-06 | 로봇 |
| CN202480063409.XA CN121941537A (zh) | 2023-08-09 | 2024-08-06 | 机器人 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2023-130253 | 2023-08-09 | ||
| JP2023130253 | 2023-08-09 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2025033437A1 true WO2025033437A1 (ja) | 2025-02-13 |
Family
ID=94533869
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2024/028120 Ceased WO2025033437A1 (ja) | 2023-08-09 | 2024-08-06 | ロボット |
Country Status (5)
| Country | Link |
|---|---|
| JP (1) | JPWO2025033437A1 (ja) |
| KR (1) | KR20260066707A (ja) |
| CN (1) | CN121941537A (ja) |
| TW (1) | TW202513132A (ja) |
| WO (1) | WO2025033437A1 (ja) |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4714445A (en) * | 1985-09-27 | 1987-12-22 | Templeton Charles B | Warmed animal toy |
| WO2008072517A1 (ja) * | 2006-12-15 | 2008-06-19 | Dow Corning Toray Co., Ltd. | 人工外皮用シリコーンエラストマー組成物 |
| JP2021161419A (ja) * | 2020-03-31 | 2021-10-11 | 日東電工株式会社 | 複合材料 |
-
2024
- 2024-08-06 WO PCT/JP2024/028120 patent/WO2025033437A1/ja not_active Ceased
- 2024-08-06 KR KR1020267005377A patent/KR20260066707A/ko active Pending
- 2024-08-06 JP JP2025539540A patent/JPWO2025033437A1/ja active Pending
- 2024-08-06 CN CN202480063409.XA patent/CN121941537A/zh active Pending
- 2024-08-07 TW TW113129512A patent/TW202513132A/zh unknown
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4714445A (en) * | 1985-09-27 | 1987-12-22 | Templeton Charles B | Warmed animal toy |
| WO2008072517A1 (ja) * | 2006-12-15 | 2008-06-19 | Dow Corning Toray Co., Ltd. | 人工外皮用シリコーンエラストマー組成物 |
| JP2021161419A (ja) * | 2020-03-31 | 2021-10-11 | 日東電工株式会社 | 複合材料 |
Non-Patent Citations (3)
| Title |
|---|
| KOBUNSHI RONBUNSHU: "Evaluation of Dynamic Compression Modulus of Micro-Cell Polyurethane Foams by Dynamic Viscoelastic Measurements", J-STAGE, J-STAGE, vol. 63, no. 4, 1 April 2006 (2006-04-01), pages 273 - 276, XP093278242 * |
| OSAWA YUKIKO, KINBARA YUHO, KAGEOKA MASAKAZU, IIDA KENJI, KHEDDAR ABDERRAHMANE: "Soft robotic shell with active thermal display", SCIENTIFIC REPORTS, NATURE PUBLISHING GROUP, US, vol. 11, no. 1, US , XP093275929, ISSN: 2045-2322, DOI: 10.1038/s41598-021-99117-y * |
| ものづくりの通販カタログ NEW町工場 [online], vol. 30. 30 March 2023, p. 204, Internet<URL:http://web.archive.org/web/20230330091223/https://www.spring-net.com/pdf/catalog_new_machi_30.pdf>, [retrieved on: 06 September 2024], non-official translation (Monozukuri mail order catalog: NEWMachi Koba) * |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2025033437A1 (ja) | 2025-02-13 |
| CN121941537A (zh) | 2026-04-28 |
| TW202513132A (zh) | 2025-04-01 |
| KR20260066707A (ko) | 2026-05-12 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| Zeng et al. | Recent progress in 3D printing piezoelectric materials for biomedical applications | |
| Yang et al. | Topographic design in wearable MXene sensors with in-sensor machine learning for full-body avatar reconstruction | |
| Kaur et al. | Toward a smart compliant robotic gripper equipped with 3D‐designed cellular fingers | |
| Gul et al. | Sensitivity-controllable liquid-metal-based pressure sensor for wearable applications | |
| Yi et al. | Digital light processing 3D printing of flexible devices: actuators, sensors and energy devices | |
| US11181984B2 (en) | Virtual reality input and haptic feedback system | |
| US11907429B2 (en) | Virtual reality glove | |
| CN104020844B (zh) | 具有线性共振致动器的触觉设备 | |
| CA2901848C (en) | Composite material used as a strain gauge | |
| Chen et al. | 3D printed carbon-fibre reinforced composite lattice structures with good thermal-dimensional stability | |
| Khanbareh et al. | Large area and flexible micro-porous piezoelectric materials for soft robotic skin | |
| Tang et al. | Advancing haptic interfaces for immersive experiences in the metaverse | |
| Nittala et al. | Next steps in epidermal computing: Opportunities and challenges for soft on-skin devices | |
| Tang et al. | 3D printing of soft and porous composite pressure sensor with monotonic and positive resistance response | |
| CN110031135A (zh) | 触觉/滑觉传感器及其制备方法、电子设备、盲文识别设备、机器人 | |
| Lu et al. | Skin-inspired flexible pressure sensor with hierarchical interlocked spinosum microstructure by laser direct writing for high sensitivity and large linearity | |
| O'Donnell et al. | All-printed smart structures: a viable option? | |
| US11048331B2 (en) | Haptic feedback device | |
| Gohlke et al. | Pneumatibles: exploring soft robotic actuators for the design of user interfaces with pneumotactile feedback | |
| Zhao et al. | High-performance porous PDMS-based piezoresistive sensor prepared by a modified microwave irradiation process | |
| Guo et al. | 3-D printed fourth-order star-like negative poisson’s ratio structure for high-sensitivity bionic flexible capacitive pressure sensor | |
| Liu et al. | Rational design of conductive pathways in flexible tactile sensors via indirect 3D-printing of liquid metal for high-precision monitoring and recognition | |
| Chen et al. | Integrated design and manufacturing of a soft robotic glove with piezoresistive sensors | |
| Wang et al. | Investment micro-casting 3D-printed multi-metamaterial for programmable multimodal biomimetic electronics | |
| Ye et al. | Design and implementation of robot skin using highly sensitive sponge sensor |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 24851860 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2025539540 Country of ref document: JP Kind code of ref document: A |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2025539540 Country of ref document: JP |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 24851860 Country of ref document: EP Kind code of ref document: A1 |