WO2023127501A1 - 制御装置、制御方法、及び制御プログラム - Google Patents
制御装置、制御方法、及び制御プログラム Download PDFInfo
- Publication number
- WO2023127501A1 WO2023127501A1 PCT/JP2022/046070 JP2022046070W WO2023127501A1 WO 2023127501 A1 WO2023127501 A1 WO 2023127501A1 JP 2022046070 W JP2022046070 W JP 2022046070W WO 2023127501 A1 WO2023127501 A1 WO 2023127501A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- image
- projection
- control device
- images
- control
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images








Classifications
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N9/00—Details of colour television systems
- H04N9/12—Picture reproducers
- H04N9/31—Projection devices for colour picture display, e.g. using electronic spatial light modulators [ESLM]
- H04N9/3179—Video signal processing therefor
- H04N9/3188—Scale or resolution adjustment
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N5/00—Details of television systems
- H04N5/74—Projection arrangements for image reproduction, e.g. using eidophor
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B64—AIRCRAFT; AVIATION; COSMONAUTICS
- B64C—AEROPLANES; HELICOPTERS
- B64C27/00—Rotorcraft; Rotors peculiar thereto
- B64C27/04—Helicopters
- B64C27/08—Helicopters with two or more rotors
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B64—AIRCRAFT; AVIATION; COSMONAUTICS
- B64C—AEROPLANES; HELICOPTERS
- B64C39/00—Aircraft not otherwise provided for
- B64C39/02—Aircraft not otherwise provided for characterised by special use
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B64—AIRCRAFT; AVIATION; COSMONAUTICS
- B64D—EQUIPMENT FOR FITTING IN OR TO AIRCRAFT; FLIGHT SUITS; PARACHUTES; ARRANGEMENT OR MOUNTING OF POWER PLANTS OR PROPULSION TRANSMISSIONS IN AIRCRAFT
- B64D47/00—Equipment not otherwise provided for
- B64D47/02—Arrangements or adaptations of signal or lighting devices
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B64—AIRCRAFT; AVIATION; COSMONAUTICS
- B64D—EQUIPMENT FOR FITTING IN OR TO AIRCRAFT; FLIGHT SUITS; PARACHUTES; ARRANGEMENT OR MOUNTING OF POWER PLANTS OR PROPULSION TRANSMISSIONS IN AIRCRAFT
- B64D47/00—Equipment not otherwise provided for
- B64D47/08—Arrangements of cameras
-
- G—PHYSICS
- G03—PHOTOGRAPHY; CINEMATOGRAPHY; ANALOGOUS TECHNIQUES USING WAVES OTHER THAN OPTICAL WAVES; ELECTROGRAPHY; HOLOGRAPHY
- G03B—APPARATUS OR ARRANGEMENTS FOR TAKING PHOTOGRAPHS OR FOR PROJECTING OR VIEWING THEM; APPARATUS OR ARRANGEMENTS EMPLOYING ANALOGOUS TECHNIQUES USING WAVES OTHER THAN OPTICAL WAVES; ACCESSORIES THEREFOR
- G03B21/00—Projectors or projection-type viewers; Accessories therefor
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/10—Simultaneous control of position or course in three dimensions
-
- G—PHYSICS
- G09—EDUCATION; CRYPTOGRAPHY; DISPLAY; ADVERTISING; SEALS
- G09G—ARRANGEMENTS OR CIRCUITS FOR CONTROL OF INDICATING DEVICES USING STATIC MEANS TO PRESENT VARIABLE INFORMATION
- G09G5/00—Control arrangements or circuits for visual indicators common to cathode-ray tube indicators and other visual indicators
-
- G—PHYSICS
- G09—EDUCATION; CRYPTOGRAPHY; DISPLAY; ADVERTISING; SEALS
- G09G—ARRANGEMENTS OR CIRCUITS FOR CONTROL OF INDICATING DEVICES USING STATIC MEANS TO PRESENT VARIABLE INFORMATION
- G09G5/00—Control arrangements or circuits for visual indicators common to cathode-ray tube indicators and other visual indicators
- G09G5/36—Control arrangements or circuits for visual indicators common to cathode-ray tube indicators and other visual indicators characterised by the display of a graphic pattern, e.g. using an all-points-addressable [APA] memory
- G09G5/37—Details of the operation on graphic patterns
- G09G5/373—Details of the operation on graphic patterns for modifying the size of the graphic pattern
-
- G—PHYSICS
- G09—EDUCATION; CRYPTOGRAPHY; DISPLAY; ADVERTISING; SEALS
- G09G—ARRANGEMENTS OR CIRCUITS FOR CONTROL OF INDICATING DEVICES USING STATIC MEANS TO PRESENT VARIABLE INFORMATION
- G09G5/00—Control arrangements or circuits for visual indicators common to cathode-ray tube indicators and other visual indicators
- G09G5/36—Control arrangements or circuits for visual indicators common to cathode-ray tube indicators and other visual indicators characterised by the display of a graphic pattern, e.g. using an all-points-addressable [APA] memory
- G09G5/37—Details of the operation on graphic patterns
- G09G5/377—Details of the operation on graphic patterns for mixing or overlaying two or more graphic patterns
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N9/00—Details of colour television systems
- H04N9/12—Picture reproducers
- H04N9/31—Projection devices for colour picture display, e.g. using electronic spatial light modulators [ESLM]
- H04N9/3141—Constructional details thereof
- H04N9/3147—Multi-projection systems
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N9/00—Details of colour television systems
- H04N9/12—Picture reproducers
- H04N9/31—Projection devices for colour picture display, e.g. using electronic spatial light modulators [ESLM]
- H04N9/3191—Testing thereof
- H04N9/3194—Testing thereof including sensor feedback
Definitions
- the present invention relates to a control device, control method, and control program.
- Patent Document 1 discloses a drone equipped with a projection device that displays a projected image on an external projection surface, and in the case where the projected image is enlarged, reduced, or deformed by movement along the direction of the air flow path, the drone describes a drone that corrects a projected image so that it has a predetermined size and shape on the projection plane according to the distance from the projection plane to the projection plane and the angle with respect to the projection plane.
- Patent Document 2 discloses a control device for controlling a moving body having a projection unit, in which at least one of the position of the moving body, the attitude of the moving body, and the direction of the projection part is determined by referring to a captured image. A controller is described for controlling the
- Patent Document 4 projection is performed based on information on the shape of the projection plane on which the image is projected, information on the position of the viewpoint from which the image projected on the projection plane is observed, and information on the position of the projection point on which the image is projected. 2. Description of the Related Art An image processing apparatus is described that estimates a visible area when an image projected onto a surface is viewed from a viewing point, and corrects the target image to fit within that area.
- One embodiment of the technology of the present disclosure provides a control device, a control method, and a control program that can perform information transmission by projecting and capturing images with high accuracy even in situations where high-precision projection and capturing are difficult. offer.
- a control device is a control device that includes a processor and controls a projection device, wherein the processor obtains a plurality of image data representing a plurality of images that become an information image by synthesis, and the projection Control is performed to project the plurality of images from the device at different timings.
- a processor of a control device that controls a projection device acquires a plurality of image data representing a plurality of images that become an information image by synthesis, and outputs the plurality of images from the projection device to different images. It controls the timing of projection.
- a control program acquires a plurality of image data representing a plurality of images to be synthesized into an information image in a processor of a control device that controls a projection device, and converts the plurality of images from the projection device into different images. It is used to control the timing of projection and to execute processing.
- control device it is possible to provide a control device, a control method, and a control program that can perform information transmission by projecting and capturing images with high accuracy even in situations where high-precision projection and capturing are difficult.
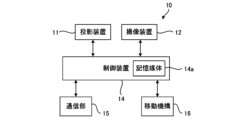
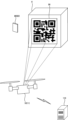
- FIG. 1 is a diagram showing an example of a configuration of a mobile body 10
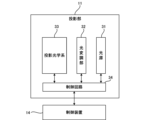
- FIG. 2 is a schematic diagram showing an example of the internal configuration of the projection device 11
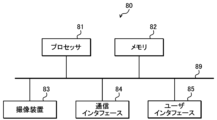
- FIG. 3 is a diagram showing an example of a hardware configuration of an information reading device 80
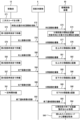
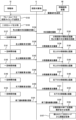
- FIG. 7 is a sequence diagram showing a first example of information transmission by second control of the control device 14
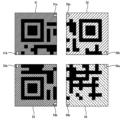
- 6 is a diagram (part 1) for explaining each operation of information transmission shown in FIG. 5
- FIG. 6 is a diagram (part 2) for explaining each operation of information transmission shown in FIG. 5
- FIG. 6 is a diagram (part 3) for explaining each operation of information transmission shown in FIG. 5;
- FIG. 1 is a diagram showing an example of a configuration of a mobile body 10
- FIG. 2 is a schematic diagram showing an example of the internal configuration of the projection device 11
- FIG. 3 is a diagram showing an example of a hardware configuration of an information reading device 80
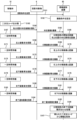
- FIG. FIG. 7 is a sequence diagram showing a first example of information transmission by second control of
- FIG. 6 is a diagram (part 4) for explaining each operation of information transmission shown in FIG. 5;
- FIG. 6 is a diagram (No. 5) for explaining each operation of information transmission shown in FIG. 5;
- FIG. 6 is a diagram (part 6) for explaining each operation of information transmission shown in FIG. 5;
- FIG. 6 is a diagram (No. 7) for explaining each operation of information transmission shown in FIG. 5;
- FIG. 6 is a diagram (part 8) for explaining each operation of information transmission shown in FIG. 5;
- FIG. 10 is a diagram showing an example of deterioration of the two-dimensional code 50 in long-distance projection under the first control;
- 4 is a diagram showing an example of measuring the distance d between the projection device 11 and the projection target 6;
- FIG. 6 is a flowchart showing an example of processing of the control device 14 based on the distance d between the projection device 11 and the projection target 6; 8 is a flowchart showing another example of processing of the control device 14 based on the distance d between the projection device 11 and the projection target 6; 9 is a flowchart showing still another example of processing of the control device 14 based on the distance d between the projection device 11 and the projection target 6; FIG. 9 is a sequence diagram showing a second example of information transmission by the second control of the control device 14; 20 is a diagram (part 1) for explaining each operation of information transmission shown in FIG. 19; FIG. 20 is a diagram (part 2) for explaining each operation of information transmission shown in FIG. 19; FIG.
- FIG. 20 is a diagram (part 3) for explaining each operation of information transmission shown in FIG. 19;
- FIG. FIG. 20 is a diagram (part 4) for explaining each operation of information transmission shown in FIG. 19;
- FIG. 20 is a diagram (No. 5) for explaining each operation of information transmission shown in FIG. 19;
- FIG. 20 is a diagram (part 6) for explaining each operation of information transmission shown in FIG. 19;
- 20 is a diagram (No. 7) for explaining each operation of information transmission shown in FIG. 19;
- FIG. FIG. 11 is a sequence diagram showing a third example of information transmission by the second control of the control device 14;
- FIG. 10 is a diagram showing an example of a situation where the projection range is restricted by an obstacle between the moving body 10 and the projection target 6;
- FIG. 11 is a sequence diagram showing a fourth example of information transmission by the second control of the control device 14;
- FIG. 14 is a sequence diagram showing a fifth example of information transmission by the second control of the control device 14; It is a figure which shows an example of the control apparatus 110 to which the control apparatus of this invention is applied.
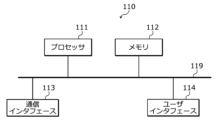
- 3 is a diagram illustrating an example of a hardware configuration of a control device 110; FIG.
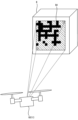
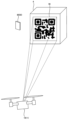
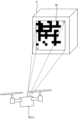
- FIG. 1 is a diagram showing an example of a moving object 10 to which the control device of the present invention can be applied.
- the moving object 10 is a movable flying object, such as an unmanned aerial vehicle called a drone.
- the moving body 10 is a multicopter having three or more rotors (eg, four rotors).
- a moving body 10 is equipped with a projection device 11 .
- the projection device 11 is a projection device capable of projecting onto the projection target 6 .
- the projection device 11 will be described with reference to FIG.
- the projection target 6 is an object such as a wall or a screen having a projection surface on which a projection image can be displayed by the projection device 11 .
- the projection target 6 is a rectangular parallelepiped.
- the projection device 11 can project an image onto the projection target 6 while the mobile object 10 is in flight.
- the control device of the present invention is mounted, for example, on the moving body 10 and controls projection by the projection device 11.
- This control device is capable of executing first control and second control.
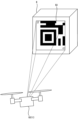
- the first control as shown in FIG. 1, is control for projecting a two-dimensional code 50 from the projection device 11 onto the projection object 6, for example.
- the two-dimensional code 50 is an example of an information image from which information can be obtained by optical reading.
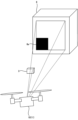
- the second control is a control for projecting a plurality of images to be the two-dimensional code 50 from the projecting device 11 onto the projection object 6 at different timings by joining processing. A specific example of the second control will be described later.
- the joining process is a process of joining a plurality of images to generate one information image, and is an example of combining a plurality of images.
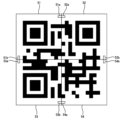
- the two-dimensional code 50 is a substantially square image with white and black areas.
- the arrangement of white areas and black areas in the two-dimensional code 50 represents information such as text information, and the information can be obtained by optically reading the arrangement of the white areas and black areas in the two-dimensional code 50. .
- the information reading device 80 is an information terminal equipped with an imaging device 83 .
- the imaging device 83 is an example of an imaging unit capable of imaging the projection target 6 .
- the imaging device 83 will be described with reference to FIG.
- the information reading device 80 may be an information terminal installed at a position where the object to be projected 6 can be imaged, or may be a smart phone or a tablet terminal that can be carried by the user.
- FIG. 2 is a diagram showing an example of the configuration of the moving body 10.
- the moving body 10 includes, for example, a projection device 11, an imaging device 12, a control device 14, a communication section 15, and a movement mechanism 16.
- the projection device 11 is configured by, for example, a liquid crystal projector or a projector using LCOS (Liquid Crystal On Silicon). In the following description, the projection device 11 is assumed to be a liquid crystal projector.
- LCOS Liquid Crystal On Silicon
- the imaging device 12 is an imaging unit including an imaging lens and an imaging device.
- the imaging element for example, a CMOS (Complementary Metal-Oxide-Semiconductor) image sensor can be used.
- CMOS Complementary Metal-Oxide-Semiconductor
- the control device 14 is an example of the control device of the present invention.
- the control device 14 performs various controls in the moving body 10 .
- Control by the control device 14 includes, for example, control of projection by the projection device 11, control of imaging by the imaging device 12, control of communication by the communication unit 15, control of movement of the moving body 10 by the movement mechanism 16, is included.
- the control device 14 includes a control unit configured by various processors, a communication interface (not shown) for communicating with each unit, and a storage medium such as a hard disk, SSD (Solid State Drive), or ROM (Read Only Memory). 14a, and controls the moving body 10 in an integrated manner.
- the various processors of the control unit of the control device 14 the circuit configuration is changed after manufacturing such as CPU (Central Processing Unit), FPGA (Field Programmable Gate Array), which is a general-purpose processor that executes programs and performs various processes.
- Programmable Logic Device which is a processor, or dedicated electric circuit, etc., which is a processor having a circuit configuration specially designed to execute specific processing such as ASIC (Application Specific Integrated Circuit) is included.
- control unit of the control device 14 may be configured with one of various processors, or a combination of two or more processors of the same or different type (for example, a combination of multiple FPGAs or a combination of a CPU and an FPGA). may consist of
- the communication unit 15 is a communication interface capable of communicating with other devices.
- the communication unit 15 is, for example, a radio communication interface that performs radio communication with an information terminal on the ground while the mobile object 10 is in flight.
- the moving mechanism 16 is a mechanism for moving the moving body 10 .
- the moving mechanism 16 includes four rotors, actuators such as motors that rotate the rotors, and control circuits that control the actuators.
- the number of rotors or the like included in the moving mechanism 16 may be three, or may be five or more.
- the projection device 11, the imaging device 12, the control device 14, the communication unit 15, and the moving mechanism 16 are implemented as, for example, one device.
- the projection device 11, the imaging device 12, the control device 14, the communication unit 15, and the movement mechanism 16 may be implemented by a plurality of devices that can cooperate by communicating with each other.
- FIG. 3 is a schematic diagram showing an example of the internal configuration of the projection device 11.
- the projection device 11 of the moving body 10 shown in FIG. 2 includes a light source 31, an optical modulator 32, a projection optical system 33, and a control circuit 34, as shown in FIG.
- the light source 31 includes a light emitting element such as a laser or an LED (Light Emitting Diode), and emits white light, for example.
- the light modulation unit 32 modulates each color light emitted from the light source 31 and separated into three colors of red, blue, and green by a color separation mechanism (not shown) based on image information, and outputs each color image. It is composed of a liquid crystal panel (light modulation element) and a dichroic prism that mixes the respective color images emitted from the three liquid crystal panels and emits them in the same direction. Red, blue, and green filters may be mounted on these three liquid crystal panels, respectively, and the white light emitted from the light source 31 may be modulated by each liquid crystal panel to emit an image of each color.
- the projection optical system 33 receives the light from the light source 31 and the light modulation section 32, and includes at least one lens and is configured by, for example, a relay optical system. The light that has passed through the projection optical system 33 is projected onto the projection target 6 .
- a region of the object to be projected 6 irradiated with the light that passes through the entire range of the light modulation section 32 is a projectable range that can be projected by the projection device 11 .
- the projection range of the projection device 11 is the area irradiated with the light that is actually transmitted from the light modulation section 32 in this projectable range. For example, by controlling the size, position, and shape of the light-transmitting region of the light modulation section 32, the size, position, and shape of the projection range of the projection device 11 change in the projectable range.
- the control circuit 34 controls the light source 31, the light modulating unit 32, and the projection optical system 33 based on the display data input from the control device 14, thereby displaying an image on the projection object 6 based on the display data. be projected.
- the display data input to the control circuit 34 is made up of three data, ie, red display data, blue display data, and green display data.
- control circuit 34 enlarges or reduces the projection range of the projection device 11 by changing the projection optical system 33 based on commands input from the control device 14 . Further, the control circuit 34 may move the projection range of the projection device 11 by changing the projection optical system 33 based on a command input from the control device 14 .
- the projection device 11 also includes a shift mechanism that mechanically or optically moves the projection range of the projection device 11 while maintaining the image circle of the projection optical system 33 .
- the image circle of the projection optical system 33 is an area in which the projection light incident on the projection optical system 33 passes through the projection optical system 33 appropriately in terms of light falloff, color separation, peripheral curvature, and the like.
- the shift mechanism is realized by at least one of an optical system shift mechanism that performs optical system shift and an electronic shift mechanism that performs electronic shift.
- the optical system shift mechanism is, for example, a mechanism for moving the projection optical system 33 in a direction perpendicular to the optical axis, or a mechanism for moving the light modulation section 32 in a direction perpendicular to the optical axis instead of moving the projection optical system 33. is. Further, the optical system shift mechanism may combine the movement of the projection optical system 33 and the movement of the light modulation section 32 .
- the electronic shift mechanism is a mechanism that shifts the pseudo projection range by changing the light transmission range in the light modulation section 32 .
- the projection device 11 may also include a projection direction changing mechanism that moves the projection range together with the image circle of the projection optical system 33 .
- the projection direction changing mechanism is a mechanism that changes the projection direction of the projection device 11 by changing the orientation of the projection device 11 by mechanical rotation.
- FIG. 4 is a diagram showing an example of the hardware configuration of the information reading device 80.
- the information reading device 80 shown in FIG. 1 includes a processor 81, a memory 82, an imaging device 83, a communication interface 84, and a user interface 85, as shown in FIG. 4, for example.
- the processor 81, memory 82, imaging device 83, communication interface 84, and user interface 85 are connected by a bus 89, for example.
- the processor 81 is a circuit that performs signal processing, and is, for example, a CPU that controls the entire information reading device 80 .
- the processor 81 may be realized by other digital circuits such as FPGA and DSP (Digital Signal Processor). Also, the processor 81 may be realized by combining a plurality of digital circuits.
- the memory 82 includes, for example, main memory and auxiliary memory.
- the main memory is, for example, RAM (Random Access Memory).
- the main memory is used as a work area for processor 81 .
- Auxiliary memory is non-volatile memory such as magnetic disk, optical disk, flash memory, etc.
- Various programs for operating the information reader 80 are stored in the auxiliary memory. Programs stored in the auxiliary memory are loaded into the main memory and executed by the processor 81 .
- the auxiliary memory may include a portable memory removable from the information reading device 80.
- Portable memories include memory cards such as USB (Universal Serial Bus) flash drives and SD (Secure Digital) memory cards, and external hard disk drives.
- the imaging device 83 is an imaging unit including an imaging lens and an imaging element.
- a CMOS image sensor can be used as the imaging device.
- the communication interface 84 is a communication interface that performs wireless communication with the outside of the information reading device 80 (for example, the mobile object 10). Communication interface 84 is controlled by processor 81 .
- the user interface 85 includes, for example, an input device that receives operation input from the user and an output device that outputs information to the user.
- the input device can be implemented by, for example, a pointing device (eg mouse), a key (eg keyboard), a remote controller, or the like.
- An output device can be realized by, for example, a display or a speaker. Also, the input device and the output device may be implemented by a touch panel or the like.
- User interface 85 is controlled by processor 81 .
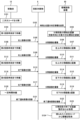
- FIG. 5 is a sequence diagram showing a first example of information transmission by the second control of the control device 14. As shown in FIG. When the control device 14 mounted on the mobile body 10 executes the second control, the mobile body 10 and the information reader 80 operate as shown in FIG. 5, for example. The operation of the mobile body 10 shown in FIG. 5 is executed by the control device 14 mounted on the mobile body 10 . 6 to 13 are diagrams for explaining each operation of information transmission shown in FIG.
- the moving body 10 divides the two-dimensional code 50 (step S11).
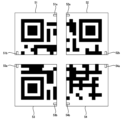
- the moving body 10 can generate each of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 shown in FIG. 6 based on the two-dimensional code data representing the two-dimensional code 50 shown in FIG. Generate image data.
- An upper left image 51, an upper right image 52, a lower left image 53, and a lower right image 54 are images obtained by dividing the two-dimensional code 50 into four. That is, the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 are a plurality of images that become the two-dimensional code 50 by the joining process.
- the moving object 10 may use different color images for the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54, respectively.
- the upper left image 51 is a red image
- the upper right image 52 is a green image
- the lower left image 53 is a blue image
- the lower right image 54 is a purple image.
- the upper left image 51 being a red image means, for example, that the white portion of the upper left image 51 obtained by dividing the two-dimensional code 50 is red, as in the example of FIG.
- the upper left image 51 being a red image may be a state in which the black portion of the upper left image 51 obtained by dividing the two-dimensional code 50 is made red.
- the white part and the black part of the upper left image 51 obtained by dividing the two-dimensional code 50 are made different reds (for example, bright red and dark red). state.
- the color of the upper left image 51 has been described, the colors of the upper right image 52, the lower left image 53, and the lower right image 54 are the same.
- the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 are images in which the white portions of the two-dimensional code 50 are red, green, blue, and purple, respectively. do.
- the moving body 10 has alignment marks 51a and 51b, alignment marks 52a and 52b, alignment marks 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53a, 53d respectively.
- 53b and alignment marks 54a and 54b may be provided.
- Alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b are used for alignment indicating the positional relationship of the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 in the above stitching process. It is an example of an image.
- the upper left image 51 and the upper right image 52 are combined.
- the upper left image 51 and the upper right image 52 can be spliced together with the vertical position of .
- the upper left image 51 and the lower left image 53 By connecting the upper left image 51 and the lower left image 53 so that the alignment mark 51b of the upper left image 51 and the alignment mark 53a of the lower left image 53 are aligned in the horizontal direction, the upper left image 51 and the lower left image 53 are combined.
- the upper left image 51 and the lower left image 53 can be spliced with the horizontal position of .
- the upper right image 52 and the lower right image 54 are connected so that the alignment mark 52b of the upper right image 52 and the alignment mark 54a of the lower right image 54 are aligned in the horizontal direction, the upper right image 52 and the lower right image 52 are combined.
- the upper right image 52 and the lower right image 54 can be spliced together in a state where the horizontal position of the image 54 is present.
- the lower left image 53 and the lower right image 54 are aligned in the vertical direction.
- the lower left image 53 and the lower right image 54 can be spliced together with the vertical position of the image 54 .
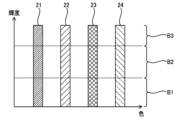
- FIG. 7 shows an example of color components of an image projected by the projection device 11.
- the horizontal direction indicates the color (wavelength) of the image projected by the projection device 11
- the vertical axis indicates the pixel value of the image projected by the projection device 11 .
- a red component 21 is a component of the red portion of the upper left image 51 .
- a green component 22 is a component of the green portion of the upper right image 52 .
- a blue component 23 is a component of the blue portion of the lower left image 53 .
- a purple component 24 is a component of the purple portion of the lower right image 54 .
- the luminance area B1 is an area that is not detected (ignored) in optical reading by the information reading device 80.
- a luminance region B3 is a luminance region of the red component 21, the green component 22, the blue component 23, and the purple component 24.
- the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, 54b can be, for example, gray images in the brightness area B2 between the brightness areas B1 and B3.
- the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b are removed to form a two-dimensional code. It becomes easy to obtain an image equivalent to 50.
- the moving object 10 is connected to each color of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 obtained by dividing in step S11, and the joining process described above.
- Corresponding images indicating the correspondence between the positions of the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 are projected from the projector 11 onto the projection object 6 (step S12).
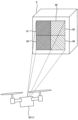
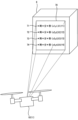
- the moving object 10 projects a corresponding image 60 shown in FIG.
- the corresponding image 60 is a substantially square image having an upper left region 61 , an upper right region 62 , a lower left region 63 and a lower right region 64 .
- the positions of the upper left region 61, the upper right region 62, the lower left region 63, and the lower right region 64 in the corresponding image 60 are the positions of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 in the two-dimensional code 50, respectively. corresponds to
- the colors of the upper left region 61, the upper right region 62, the lower left region 63, and the lower right region 64 in the corresponding image 60 are the colors of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 in the two-dimensional code 50.
- Corresponding to the colors are red, green, blue and purple, respectively.
- the information reading device 80 optically reads the corresponding image 60 with the imaging device 83, and the corresponding images are such that the red image is the upper left, the green image is the upper right, the blue image is the lower left, and the purple image is the lower right. Able to recognize relationships.
- the corresponding image 60 also serves as notification information for notifying the information reading device 80 of the start of split display (second control) of the two-dimensional code 50 .
- the information reading device 80 is configured to recognize that split display of the two-dimensional code 50 is started when an image in which a plurality of regions with different colors are arranged in tiles like the corresponding image 60 is captured. ing.
- the corresponding image 60 includes a predetermined marker image or the like for notifying the start of split display (second control) of the two-dimensional code 50 and the information reading device 80 captures the predetermined marker image or the like
- the two-dimensional code 50 may be configured to recognize when split display of is started.
- the information reading device 80 captures the corresponding image 60 projected onto the projection target 6 (step S13).
- the information reading device 80 recognizes the start of split display (second control) of the two-dimensional code 50, and recognizes the correspondence between the color and the position (step S14).
- the information reading device 80 recognizes the corresponding relationship that the red image is on the upper left, the green image is on the upper right, the blue image is on the lower left, and the purple image is on the lower right.
- the moving object 10 waits for a certain period of time from step S12 (step S15), enlarges the upper left red image 51 among the divided images obtained by dividing in step S11, and projects it from the projector 11 to the projection object 6. (step S16). For example, as shown in FIG. 9, the moving object 10 enlarges the upper left image 51 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the upper left image 51 projected onto the projection target 6 (step S17).
- the information reading device 80 recognizes the upper left image 51 as the upper left divided image because the upper left image 51 captured in step S17 is red, based on the correspondence between the colors and positions recognized in step S14. (Step S18).
- the moving body 10 waits for a certain period of time from step S15 (step S19), enlarges the green upper right image 52 among the divided images obtained by dividing in step S11, and projects it from the projection device 11 to the projection object 6. (step S20). For example, as shown in FIG. 10, the moving object 10 enlarges the upper right image 52 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the upper right image 52 projected onto the projection object 6 (step S21).
- the information reading device 80 recognizes the upper right image 52 as the upper right divided image because the upper right image 52 captured in step S21 is green, based on the correspondence between the colors and positions recognized in step S14. (Step S22).
- the moving body 10 waits for a certain period of time from step S19 (step S23), expands the blue lower left image 53 among the divided images obtained by dividing in step S11, and projects it from the projection device 11 to the projection object 6. (step S24). For example, as shown in FIG. 11, the moving object 10 enlarges the lower left image 53 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the lower left image 53 projected onto the projection target 6 (step S25).
- the information reading device 80 recognizes the lower left image 53 as the lower left divided image because the lower left image 53 captured in step S25 is blue, based on the correspondence between the colors and positions recognized in step S14. (Step S26).
- the moving body 10 waits for a certain period of time from step S23 (step S27), enlarges the lower right purple image 54 among the divided images obtained by dividing in step S11, and outputs the image from the projection device 11 to the object to be projected. 6 (step S28). For example, as shown in FIG. 12, the moving body 10 enlarges the lower right image 54 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the lower right image 54 projected onto the projection target 6 (step S29).
- the information reading device 80 detects that the lower right image 54 captured in step S29 is purple, so that the lower right image 54 is replaced with the lower right divided image. (step S30).
- step S31 the moving body 10 waits for a certain period of time from step S27 (step S31), and projects an end notification image from the projection device 11 onto the projection object 6 to notify the end of the divided display (second control) of the two-dimensional code 50. (step S32).
- the end notification image is, for example, the same image as the corresponding image 60 projected in step S12.
- the information reading device 80 is configured to recognize the end of split display of the two-dimensional code 50 when the second projection of the corresponding image 60 is detected.
- the end notification image is a predetermined marker image or the like for notifying the end of split display (second control) of the two-dimensional code 50, and when the information reading device 80 captures the predetermined marker image or the like, the two-dimensional code It may be configured to recognize the end of 50 split displays.
- the information reading device 80 captures the end notification image projected on the projection target 6 (step S33). Next, the information reading device 80 recognizes the end of split display, and joins the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 obtained by imaging (step S34).
- the information reading device 80 performs a splicing process as shown in FIG. Specifically, based on the recognition results of steps S18, S22, S26, and S30, the information reading device 80 converts the upper left image 51 to the upper left, the upper right image 52 to the upper right, the lower left image 53 to the lower left, and the lower right image 54 to the right. Place below.
- the information reading device 80 also uses the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b to determine the relative positions of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54, respectively. Fine tune the position. As a result, the state shown in FIG. 13 is obtained.
- the information reading device 80 also performs a process of returning the colors of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 to the original white and black. For example, the information reading device 80 performs a process of converting the red area in the upper left image 51 to white. The information reading device 80 also performs a process of removing the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, 54b. For example, the information reader 80 performs a process of converting the areas of the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b to white.
- the information reading device 80 can obtain two-dimensional code data representing a two-dimensional code equivalent to the two-dimensional code 50 shown in FIG.
- the information reading device 80 acquires information from the two-dimensional code data representing the two-dimensional code obtained by the joining process (step S35), and ends the series of processes. Accordingly, information equivalent to that of the first control can be transmitted from the moving body 10 to the information reading device 80 .
- step S14 the information reading device 80 recognizes the division number of the division display (4 in this example), and by capturing the divided image corresponding to the recognized division number, the division display of the two-dimensional code 50 ends.
- the division display of the two-dimensional code 50 ends.
- steps S31 to S33 may be omitted.
- control device 14 connects a plurality of images (for example, the upper left image 51, the upper right image 52, the lower left image 53, and the right image) into an information image (for example, an image equivalent to the two-dimensional code 50) by joining (synthesizing).
- the lower image 54 is controlled to be projected from the projection device 11 at different timings.
- control device 14 sets the plurality of images to be the information images by the joining process to images of different colors, and outputs the plurality of images, the colors of the plurality of images, and the plurality of images in the joining process from the projection device 11 .
- a corresponding image 60 indicating a correspondence relationship with the position of the image is projected at different timings. Accordingly, the above-described correspondence relationship can be transmitted from the control device 14 to the information reading device 80 without prior communication between the control device 14 and the information reading device 80 .
- control device 14 may include alignment images (for example, alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b) in a plurality of images that become information images through the joining process.
- alignment images for example, alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b
- FIG. 14 is a diagram showing an example of deterioration of the two-dimensional code 50 in long-distance projection under the first control.
- the telephoto performance of the projection optical system 33, blurring, air fluctuation, etc. may affect the projection device 11 by the first control.
- the two-dimensional code 50 is projected onto the projection object 6 from the projection object 6, the two-dimensional code 50 projected onto the projection object 6 may deteriorate greatly. In this case, even if the information reader 80 captures an image of the two-dimensional code 50 , the information reader 80 may not be able to acquire information from the two-dimensional code 50 .
- FIG. 15 is a diagram showing an example of measurement of the distance d between the projection device 11 and the projection object 6.
- a control device 14 mounted on the mobile body 10 measures the distance d between the projection device 11 (mobile body 10 ) and the projection target 6 .
- the control device 14 measures the distance d using a distance measuring means that the imaging device 12 has for AF (Auto Focus) or the like.
- the distance measurement means may be a phase difference detection type distance measurement means or a contrast type distance measurement means.
- the control device 14 may measure the distance d using a distance measuring device such as TOF (Time Of Flight) mounted on the moving body 10 .
- the control device 14 may measure the distance d by image recognition based on imaging data obtained by the imaging device 12 .
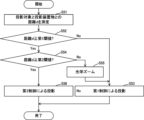
- FIG. 16 is a flow chart showing an example of processing of the control device 14 based on the distance d between the projection device 11 and the projection object 6. As shown in FIG. The control device 14 executes the processing shown in FIG. 16, for example.
- the control device 14 measures the distance d between the projection device 11 (moving body 10) and the projection target 6 (step S41). Next, the control device 14 determines whether or not the distance d measured in step S41 is greater than or equal to a predetermined first threshold (step S42).
- the first threshold is set near the shortest distance d at which information transmission by the first control becomes difficult, taking into consideration the performance of the projection device 11 and the information reading device 80, for example.
- step S42 if the distance d is not equal to or greater than the first threshold (step S42: No), the control device 14 performs, for example, the first control shown in FIG. 1 (step S43), and ends the series of processes. That is, the control device 14 performs first control to project the two-dimensional code 50 from the projection device 11 .
- step S42 when the distance d is equal to or greater than the first threshold (step S42: Yes), the control device 14 performs the second control described with reference to FIGS. finish. That is, the control device 14 performs the second control for sequentially projecting the upper left image 51 , the upper right image 52 , the lower left image 53 and the lower right image 54 (a plurality of images) from the projection device 11 .
- the control device 14 performs the first control for projecting the two-dimensional code 50 from the projection device 11 based on the distance d between the projection device 11 and the projection target 6, and the upper left image 51 and the upper right image from the projection device 11.
- the second control for projecting the image 52, the lower left image 53, and the lower right image 54 (a plurality of images) at different timings is switched.
- FIG. 17 is a flowchart showing another example of processing of the control device 14 based on the distance d between the projection device 11 and the projection object 6.
- FIG. The control device 14 may execute the processing shown in FIG. 17, for example.
- Steps S51 to S53 shown in FIG. 17 are the same as steps S41 to S43 shown in FIG.
- the control device 14 determines whether or not the distance d is greater than or equal to the second threshold (step S54).
- the second threshold is a value larger than the first threshold.
- the second threshold value is determined, for example, in consideration of the performance of the projection device 11 and the information reading device 80, so that information can be transmitted by the first control by performing optical zooming of the projection optical system 33 of the projection device 11. is set near the longest distance d.
- the second threshold may be dynamically set based on the current optical zoom state (zoomable amount) of the projection optical system 33 of the projection device 11 .
- step S54 if the distance d is greater than or equal to the second threshold (step S54: Yes), the control device 14 proceeds to step S56.
- Step S56 is the same process as step S44 shown in FIG.
- step S54 if the distance d is not equal to or greater than the second threshold (step S54: No), the control device 14 can project the two-dimensional code 50 onto the projection object 6 with a quality that can be read by the information reading device 80. As shown, the projection optical system 33 is optically zoomed (step S55), and the process proceeds to step S53.
- FIG. 18 is a flowchart showing still another example of the processing of the control device 14 based on the distance d between the projection device 11 and the projection object 6.
- the control device 14 may execute the processing shown in FIG. 18, for example.
- Steps S61 to S63 shown in FIG. 18 are the same as steps S41 to S43 shown in FIG.
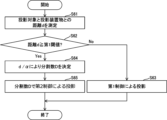
- the control device 14 determines the division number D by the formula d/ ⁇ (step S64). For example, the control device 14 is set with 4, 9, 16, etc. as candidates for the number of divisions D, and the control device 14 selects the candidate for the number of divisions D that is closest to the calculation result of d/ ⁇ . The number of divisions is determined as the number of divisions D.
- ⁇ is a predetermined coefficient greater than 1;
- Step S65 is the same process as step S44 shown in FIG. However, in step S65, the control device 14 performs projection according to the second control with the number of divisions D determined in step S64.
- the second control of the number of divisions D is to divide the two-dimensional code 50 into the number of divisions D and perform divided projection.
- the control device 14 sets the number of images (division number D) included in the plurality of images obtained by dividing the two-dimensional code 50 based on the distance d between the projection device 11 and the projection target 6.
- the controller 14 increases the number of images (the number of divisions) as the distance d increases.
- the distance d between the projection device 11 and the object 6 to be projected is short and high-precision projection is possible, projection can be performed with a smaller number of divisions D, so that information can be transmitted in a short time. can be done.
- FIG. 19 is a sequence diagram showing a second example of information transmission by the second control of the control device 14. As shown in FIG. Although the configuration in which the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 obtained by dividing the two-dimensional code 50 are images of different colors has been described, the configuration is not limited to this.
- the projection timings of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 for example, projection time, elapsed time from the reference time, etc.
- a corresponding image showing the correspondence relationship with the positions of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 in the above stitching process may be projected onto the projection object 6.
- the mobile body 10 and the information reader 80 operate as shown in FIG. 20 to 26 are diagrams for explaining each operation of information transmission shown in FIG.
- the moving body 10 divides the two-dimensional code 50 (step S71).
- the moving object 10 generates the upper left image 51, the upper right image 52, the lower left image 53, the lower right image 54, and the upper left image 51 shown in FIG.
- Generate each image data representing The upper left image 51, upper right image 52, lower left image 53, and lower right image 54 shown in FIG. 20 are similar to the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 shown in FIG. , are images of the same color (black and white images).
- the moving object 10 projects the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 obtained by dividing in step S71, and the connection timings described above.
- the projection device 11 projects a corresponding image showing the correspondence between the positions of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 in the matching process onto the projection object 6 (step S72).
- the moving object 10 projects the corresponding image 70 shown in FIG.
- the corresponding image 70 includes a first projection time position image 71 , a second projection time position image 72 , a third projection time position image 73 and a fourth projection time position image 74 .
- the first projection time position image 71 includes the first projection time (*hour*minute*second), which is the projection time of the upper left image 51, and the position coordinates (x1, y1, X1, Y1) of the upper left image 51 in the stitching process. and are shown in text.
- the position coordinates (x1, y1, X1, Y1) are coordinates indicating, for example, the upper left area in the image after the stitching process.
- the second projection time position image 72 is composed of the second projection time (*hour*minute*second), which is the projection time of the upper right image 52, and the position coordinates (x2, y2, X2, Y2) of the upper right image 52 in the stitching process. and are shown in text.
- the position coordinates (x2, y2, X2, Y2) are coordinates indicating, for example, the upper right area in the image after the stitching process.
- the third projection time position image 73 is the third projection time (*hour*minute*second), which is the projection time of the lower left image 53, and the position coordinates (x3, y3, X3, Y3) of the lower left image 53 in the stitching process. and are shown in text.
- the position coordinates (x3, y3, X3, Y3) are coordinates indicating, for example, the lower left area in the image after the joining process.
- the fourth projection time position image 74 includes the fourth projection time (*hour*minute*second), which is the projection time of the lower right image 54, and the position coordinates (x4, y4, X4, Y4) and are shown in text.
- the position coordinates (x4, y4, X4, Y4) are coordinates indicating, for example, the lower right area in the image after the stitching process.
- the information reading device 80 optically reads the corresponding image 70 with the imaging device 83 and performs character recognition processing, so that the image projected at the first projection time (*hour*minute*second) is the position coordinates (x1, y1, X1, Y1), the image projected at the second projection time (*hour*minute*second) is the position coordinate (x2, y2, X2, Y2), the third projection time (*hour*minute*) second) is called position coordinates (x3, y3, X3, Y3), and the image projected at the fourth projection time (*hour*minute*second) is called position coordinate (x4, y4, X4, Y4). Correspondence can be recognized.
- the corresponding image 70 also serves as notification information for notifying the information reading device 80 of the start of split display (second control) of the two-dimensional code 50 .
- the information reading device 80 is configured to recognize that split display of the two-dimensional code 50 is started when an image having text information indicating the correspondence relationship between projection time and position coordinates, such as the corresponding image 70, is captured. It is
- the information reading device 80 captures the corresponding image 70 projected onto the projection target 6 (step S73).
- the information reading device 80 recognizes the start of split display (second control) of the two-dimensional code 50 based on the imaging result of the corresponding image 70, and recognizes the correspondence relationship between the projection time and the position. (Step S74).
- the moving body 10 waits until the first projection time shown in the first projection time position image 71 (step S75), and enlarges the upper left image 51 among the divided images obtained by dividing in step S71. Projection is performed from the projection device 11 onto the object to be projected 6 (step S76). For example, as shown in FIG. 22, the moving object 10 enlarges the upper left image 51 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the upper left image 51 projected onto the projection target 6 (step S77). Next, based on the correspondence relationship between the projection times and positions recognized in step S74, the information reading device 80 determines that the upper left image 51 is projected as the upper left divided image because the upper left image 51 is projected at the first projection time. recognize (step S78).
- the moving body 10 waits until the second projection time shown in the second projection time position image 72 (step S79), and enlarges the upper right image 52 among the divided images obtained by dividing in step S71. Projection is performed from the projection device 11 onto the object to be projected 6 (step S80). For example, as shown in FIG. 23, the moving body 10 enlarges the upper right image 52 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the upper right image 52 projected onto the projection target 6 (step S81). Next, based on the correspondence relationship between the projection time and the position recognized in step S74, the information reading device 80 detects that the upper right image 52 is projected at the second projection time. recognize (step S82).
- the moving body 10 waits until the third projection time shown in the third projection time position image 73 (step S83), and enlarges the lower left image 53 among the divided images obtained by dividing in step S71. Projection is performed from the projection device 11 onto the object to be projected 6 (step S84). For example, as shown in FIG. 24, the moving body 10 enlarges the lower left image 53 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the lower left image 53 projected onto the projection target 6 (step S85). Next, based on the correspondence relationship between the projection time and the position recognized in step S74, the information reading device 80 detects the lower left image 53 as the lower left divided image because the lower left image 53 is projected at the third projection time. recognize (step S86).
- the moving body 10 waits until the fourth projection time shown in the fourth projection time position image 74 (step S87), and enlarges the lower right image 54 among the divided images obtained by dividing in step S71. Then, the image is projected from the projection device 11 onto the projection object 6 (step S88). For example, as shown in FIG. 25, the moving body 10 enlarges the lower right image 54 to the same size as the two-dimensional code 50 shown in FIG.
- the information reading device 80 captures the lower right image 54 projected onto the projection target 6 (step S89). Next, based on the correspondence relationship between the projection time and the position recognized in step S74, the information reading device 80 detects that the lower right image 54 is projected at the fourth projection time. It is recognized as a divided image (step S90).
- Steps S91 to S95 are the same as steps S31 to S35 shown in FIG.
- the information reading device 80 performs a joining process as shown in FIG. 26, for example. Specifically, based on the recognition results of steps S78, S82, S86, and S90, the information reading device 80 moves the upper left image 51 to the upper left, the upper right image 52 to the upper right, the lower left image 53 to the lower left, and the lower right image 54 to the right. Place below.
- the information reading device 80 also uses the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, and 54b to determine the relative positions of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54, respectively. Fine tune the position. As a result, an image in the state shown in FIG. 26 is obtained.
- the information reading device 80 may perform a process of removing the alignment marks 51a, 51b, 52a, 52b, 53a, 53b, 54a, 54b. Thereby, the information reading device 80 can obtain two-dimensional code data representing a two-dimensional code equivalent to the two-dimensional code 50 shown in FIG.
- the control device 14 controls the projection timing of the plurality of divided images (the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54), the projection timing of the plurality of images, and the A corresponding image 70 indicating the correspondence relationship with the positions of a plurality of images may be projected at different timings. Accordingly, the above-described correspondence relationship can be transmitted from the control device 14 to the information reading device 80 without prior communication between the control device 14 and the information reading device 80 . In addition, since it is possible to omit color-coding of the projected image, color extraction from the captured image, and the like, it is possible to simplify the configurations of the projection device 11 and the information reading device 80 .
- FIG. 27 is a sequence diagram showing a third example of information transmission by the second control of the control device 14. As shown in FIG. Although the configuration in which the moving body 10 notifies the information reading device 80 of the correspondence relationship between the projection time and the position by projecting the corresponding image 70 has been described, the configuration is not limited to this.
- the projection timings of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 (for example, projection time, elapsed time from the reference time, etc.) and , correspondence information indicating the correspondence between the positions of the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 in the splicing process may be transmitted to the information reading device 80.
- FIG. For example, the mobile body 10 and the information reader 80 operate as shown in FIG.
- the moving body 10 divides the two-dimensional code 50 (step S101).
- the division of the two-dimensional code 50 in step S101 is similar to the division of the two-dimensional code 50 shown in FIGS. 19 and 20, for example.
- the moving body 10 projects the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 obtained by dividing in step S101, and the upper left image 51, Correspondence information indicating the correspondence between the positions of the upper right image 52, the lower left image 53, and the lower right image 54 is transmitted to the information reading device 80 (step S102).
- the correspondence information is transmitted from the mobile unit 10 to the information reader 80 by wireless communication between the communication unit 15 of the mobile unit 10 and the communication interface 84 of the information reader 80, for example.
- the correspondence information also serves as notification information for notifying the information reading device 80 of the start of split display (second control) of the two-dimensional code 50 .
- the information reading device 80 is configured to recognize that split display of the two-dimensional code 50 will start when the corresponding information is received.
- Step S103 the information reading device 80 recognizes the start of split display (second control) of the two-dimensional code 50, and determines the correspondence relationship between the projection time and the position. recognize (step S103).
- Steps S104 to S124 are the same processes as steps S75 to S95 shown in FIG. However, instead of steps S120 to S122, a process of transmitting end notification information for notifying the end of the split display (second control) of the two-dimensional code 50 from the moving body 10 to the information reading device 80 may be performed.
- the transmission of the end notification information from the mobile body 10 to the information reader 80 is performed by wireless communication between the communication unit 15 of the mobile body 10 and the communication interface 84 of the information reader 80, for example.
- control device 14 controls the projection timings of the plurality of divided images (the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54) and the positions of the plurality of images in the joining process. You may perform control which transmits the correspondence information which shows the correspondence with to the information reader 80.
- FIG. 1
- FIG. 28 is a diagram showing an example of a situation in which an obstacle between the moving body 10 and the projection target 6 limits the projection range.
- the obstacle 3 between the moving body 10 and the projection target 6 causes a shadow 6a on the projection target 6, and no image is projected on the shadow 6a portion of the projection target 6.
- the moving body 10 can notify the information reading device 80 of the correspondence relationship between the projection timing and the position.
- control device 14 recognizes the obstacle 3 or the shadow 6a by image recognition processing based on the imaging data obtained by the imaging device 12, and projects it onto the part of the object to be projected 6 excluding the shadow 6a. perform control.
- FIG. 29 is a sequence diagram showing a fourth example of information transmission by the second control of the control device 14.
- the control device 14 may receive information indicating the imaging conditions of the imaging device 83 of the information reading device 80 from the information reading device 80 and perform projection by the second control based on the imaging conditions of the imaging device 83 .
- the mobile body 10 and the information reader 80 operate as shown in FIG.
- the information reading device 80 transmits information indicating imaging conditions to the moving body 10 (step S131).
- the imaging conditions are, for example, the frame rate and exposure time (shutter speed) of imaging. Transmission of information indicating imaging conditions from the information reader 80 to the mobile body 10 is performed by wireless communication between the communication interface 84 of the information reader 80 and the communication unit 15 of the mobile body 10, for example.
- the moving body 10 sets the frame rate and projection timing of projection by the projection device 11 based on the imaging conditions of the imaging device 83 indicated by the information received in step S131 (step S132).
- the frame rate of projection for example, the projection device 11 repeatedly projects the same image to project the image as a still image, and the frame rate of projection is the repetition speed of the projection.
- the projection timings are, for example, projection timings of the corresponding image 60, the upper left image 51, the upper right image 52, the lower left image 53, the lower right image 54, and the end notification image.
- the moving body 10 sets a frame rate equal to or lower than the frame rate for imaging by the imaging device 83 as the frame rate for projection by the projection device 11 .
- the information reading device 80 reads the corresponding image 60, the upper left image 51, the upper right image 52, the lower left image 53, the lower right image 54, and the moving object 10.
- Each projection timing by the projection device 11 is set so that each end notification image can be recognized.
- Steps S133 to S157 are the same processes as steps S11 to S35 shown in FIG. However, in steps S134, S138, S142, S146, S150, and S154, the moving body 10 performs projection at the frame rate and projection timing set in step S132.
- control device 14 receives information indicating the imaging conditions of the imaging device 83 of the information reading device 80 from the information reading device 80, and based on the imaging conditions of the imaging device 83, selects each image including a plurality of images. Projection may be performed.
- the moving body 10 can set appropriate projection conditions in the imaging device 83 according to the imaging conditions of the imaging device 83 and perform projection.
- FIG. 30 is a sequence diagram showing a fifth example of information transmission by the second control of the control device 14.
- the control device 14 may transmit information indicating conditions for projecting an image by the projection device 11 to the information reading device 80 .
- the mobile body 10 and the information reader 80 operate as shown in FIG.
- the moving body 10 transmits information indicating conditions for projecting an image by the projection device 11 to the information reading device 80 (step S161).
- Projection conditions include, for example, the frame rate and luminance of projection. Transmission of the information indicating the projection conditions from the moving body 10 to the information reading device 80 is performed by wireless communication between the communication unit 15 of the moving body 10 and the communication interface 84 of the information reading device 80, for example.
- the information reading device 80 sets the imaging conditions of the imaging device 83 based on the projection conditions indicated by the information received in step S161 (step S162). For example, the information reading device 80 sets a frame rate equal to or higher than the frame rate of projection by the projection device 11 as the frame rate of imaging by the imaging device 83 . Also, the lower the brightness of the projection by the projection device 11, the higher (brighter) the exposure is set.
- Steps S163 to S187 are the same processes as steps S11 to S35 shown in FIG. However, in steps S165, S169, S173, S177, S181, and S185, the imaging device 83 of the moving body 10 performs imaging under the imaging conditions set in step S162.
- control device 14 may control transmission of information indicating the conditions for projecting an image by the projection device 11 to the information reading device 80 .
- the information reading device 80 can set the imaging condition corresponding to the projection condition of the image by the projection device 11 to the imaging device 83 and capture the image projected by the projection device 11 .
- control device of the present invention is applied to the control device 14 of the moving body 10
- the configuration is not limited to this.
- FIG. 31 is a diagram showing an example of a control device 110 to which the control device of the present invention is applied.
- the control device of the present invention may be applied to the control device 110 shown in FIG. 31, for example.
- the control device 110 is a device that can directly or indirectly communicate with the mobile object 10 .
- Communication between the control device 110 and the projection device 11 is, for example, wireless communication.
- Communication between the control device 110 and the projection device 11 may be direct communication, or may be communication via another communication device or network.
- the control device 110 communicates with the mobile object 10 to execute various controls similar to those of the control device 14 described above.
- the control device 110 can be various devices such as a server device, a desktop personal computer, a notebook personal computer, a smart phone, and a tablet terminal.
- FIG. 32 is a diagram showing an example of the hardware configuration of the control device 110.
- the control device 110 shown in FIG. 31 includes, for example, a processor 111, a memory 112, a communication interface 113, and a user interface 114 as shown in FIG.
- Processor 111 , memory 112 , communication interface 113 and user interface 114 are connected by bus 119 , for example.
- the processor 111, memory 112, communication interface 113, and user interface 114 have the same configurations as the processor 81, memory 82, communication interface 84, and user interface 85 of the information reading device 80 shown in FIG. 4, for example.
- the communication interface 113 communicates with the mobile unit 10, for example.
- the information image is not limited to this.
- the information image may be a two-dimensional code in a format different from the two-dimensional code 50, or may be a one-dimensional code.
- the configuration in which the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 are images obtained by dividing the two-dimensional code 50 has been described, the configuration is not limited to this.
- the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 may be images stored in advance in the control device 14 or another device.
- the two-dimensional code obtained by synthesizing the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 projected under the second control is completely the same as the two-dimensional code 50 projected under the first control. It does not have to be the same image, as long as it is an image from which substantially the same information as the two-dimensional code 50 can be obtained by being read by the information reading device 80 .
- each of the upper left image 51, upper right image 52, lower left image 53, and lower right image 54 is enlarged to the same size as the two-dimensional code 50 and projected. do not have.
- the control device 14 may project the upper left image 51, the upper right image 52, the lower left image 53, and the lower right image 54 by slightly enlarging them.
- synthesizing process for obtaining an information image from a plurality of images a stitching process for arranging and combining a plurality of images has been described, but the synthesizing process for obtaining an information image from a plurality of images is not limited to this.
- the synthesizing process of obtaining an information image from a plurality of images may be a process of arranging and synthesizing a plurality of images so as to partially overlap each other.
- the moving object 10 is a multicopter
- the moving object 10 may be an aircraft (flying object) other than the multicopter.
- the moving object 10 is not limited to a flying object, and may be a vehicle, a robot, or the like that runs or walks on the ground.
- the configuration in which the projection device 11 is mounted on the moving body 10 has been described, the configuration is not limited to this.
- the projection device 11 may be a projection device fixed on the ground.
- a control device comprising a processor, for controlling a projection device,
- the above processor Acquiring a plurality of image data representing a plurality of images that become an information image by synthesis, performing control to project the plurality of images from the projection device at different timings; Control device.
- the control device includes a first image and a second image;
- the above processor projecting the first image at an earlier timing than the second image; After the timing of the end of projection of the first image, start projection of the second image; Control device.
- the control device performs first control for projecting the information image from the projection device and second control for projecting the plurality of images from the projection device at different timings based on the distance between the projection device and the projection target. , toggle Control device.
- the control device is capable of changing the focal length of projection,
- the processor switches between the first control and the second control based on a distance between the projection device and the projection target and a changeable range of the focal length. Control device.
- the control device controls the projecting device to project the plurality of images and a corresponding image indicating a correspondence relationship between the colors of the plurality of images and the positions of the plurality of images in the synthesis at different timings. , Control device.
- the control device performs control to project the plurality of images and a corresponding image indicating a correspondence relationship between projection timings of the plurality of images and positions of the plurality of images in the synthesis at different timings. Control device.
- control device capable of communicating with an information reading device having an imaging unit capable of imaging an object to be projected;
- the processor controls transmission of correspondence information indicating a correspondence relationship between projection timings of the plurality of images and positions of the plurality of images in the synthesis to the information reading device. Control device.
- At least one of the plurality of images includes an alignment image indicating the positional relationship of the plurality of images in the synthesis; Control device.
- the control device according to any one of (1) to (8), The processor sets the number of images included in the plurality of images based on the distance between the projection device and the projection target. Control device.
- control device capable of communicating with an information reading device having an imaging unit capable of imaging an object to be projected by the projection device;
- the processor receives information indicating imaging conditions of the imaging unit from the information reading device, and causes the projection device to project the plurality of images based on the imaging conditions. Control device.
- control device capable of communicating with an information reading device having an imaging unit capable of imaging an object to be projected by the projection device;
- the processor controls transmission of information indicating projection conditions of the plurality of images by the projection device to the information reading device. Control device.
- the control device according to any one of (1) to (11),
- the projection device is mounted on a moving body, Control device.
- control device according to any one of (1) to (12), The processor controls the projection device to project the plurality of images and an image different from the plurality of images at different timings. Control device.
- a processor of a control device that controls the projection device, Acquiring a plurality of image data representing a plurality of images that become an information image by synthesis, performing control to project the plurality of images from the projection device at different timings; control method.
Landscapes
- Engineering & Computer Science (AREA)
- Multimedia (AREA)
- Signal Processing (AREA)
- Physics & Mathematics (AREA)
- Aviation & Aerospace Engineering (AREA)
- General Physics & Mathematics (AREA)
- Theoretical Computer Science (AREA)
- Computer Hardware Design (AREA)
- Mechanical Engineering (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Automation & Control Theory (AREA)
- Projection Apparatus (AREA)
- Lighting Device Outwards From Vehicle And Optical Signal (AREA)
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2023570822A JPWO2023127501A1 (cg-RX-API-DMAC7.html) | 2021-12-27 | 2022-12-14 | |
| US18/755,100 US20240348741A1 (en) | 2021-12-27 | 2024-06-26 | Control device, control method, and control program |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021-212602 | 2021-12-27 | ||
| JP2021212602 | 2021-12-27 |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| US18/755,100 Continuation US20240348741A1 (en) | 2021-12-27 | 2024-06-26 | Control device, control method, and control program |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2023127501A1 true WO2023127501A1 (ja) | 2023-07-06 |
Family
ID=86998749
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/046070 Ceased WO2023127501A1 (ja) | 2021-12-27 | 2022-12-14 | 制御装置、制御方法、及び制御プログラム |
Country Status (3)
| Country | Link |
|---|---|
| US (1) | US20240348741A1 (cg-RX-API-DMAC7.html) |
| JP (1) | JPWO2023127501A1 (cg-RX-API-DMAC7.html) |
| WO (1) | WO2023127501A1 (cg-RX-API-DMAC7.html) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102023133519A1 (de) * | 2023-11-30 | 2025-06-05 | Audi Aktiengesellschaft | Verfahren zum Betreiben eines unbemannten Luftfahrzeugs einer Kraftfahrzeugladestation, unbemanntes Luftfahrzeug sowie Kraftfahrzeugladestation |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2003288558A (ja) * | 2002-03-27 | 2003-10-10 | Denso Wave Inc | 2次元コード表示方法、2次元コード表示装置、2次元コード読取方法及び2次元コード読取装置 |
| US20060279477A1 (en) * | 2005-06-10 | 2006-12-14 | Allen William J | Adjusting light intensity |
| JP2007096542A (ja) * | 2005-09-27 | 2007-04-12 | Sharp Corp | プロジェクタ機能付携帯端末 |
| JP2016024576A (ja) * | 2014-07-18 | 2016-02-08 | 日本電信電話株式会社 | 送信装置及び情報伝送方法 |
| JP2016062260A (ja) * | 2014-09-17 | 2016-04-25 | 株式会社デンソーウェーブ | 情報コード読取システムおよび情報コード表示装置 |
| WO2021045040A1 (ja) * | 2019-09-02 | 2021-03-11 | 株式会社デンソーウェーブ | 情報コード読取システム |
-
2022
- 2022-12-14 WO PCT/JP2022/046070 patent/WO2023127501A1/ja not_active Ceased
- 2022-12-14 JP JP2023570822A patent/JPWO2023127501A1/ja active Pending
-
2024
- 2024-06-26 US US18/755,100 patent/US20240348741A1/en active Pending
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2003288558A (ja) * | 2002-03-27 | 2003-10-10 | Denso Wave Inc | 2次元コード表示方法、2次元コード表示装置、2次元コード読取方法及び2次元コード読取装置 |
| US20060279477A1 (en) * | 2005-06-10 | 2006-12-14 | Allen William J | Adjusting light intensity |
| JP2007096542A (ja) * | 2005-09-27 | 2007-04-12 | Sharp Corp | プロジェクタ機能付携帯端末 |
| JP2016024576A (ja) * | 2014-07-18 | 2016-02-08 | 日本電信電話株式会社 | 送信装置及び情報伝送方法 |
| JP2016062260A (ja) * | 2014-09-17 | 2016-04-25 | 株式会社デンソーウェーブ | 情報コード読取システムおよび情報コード表示装置 |
| WO2021045040A1 (ja) * | 2019-09-02 | 2021-03-11 | 株式会社デンソーウェーブ | 情報コード読取システム |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102023133519A1 (de) * | 2023-11-30 | 2025-06-05 | Audi Aktiengesellschaft | Verfahren zum Betreiben eines unbemannten Luftfahrzeugs einer Kraftfahrzeugladestation, unbemanntes Luftfahrzeug sowie Kraftfahrzeugladestation |
Also Published As
| Publication number | Publication date |
|---|---|
| US20240348741A1 (en) | 2024-10-17 |
| JPWO2023127501A1 (cg-RX-API-DMAC7.html) | 2023-07-06 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP3867205B2 (ja) | 指示位置検出装置、及び指示位置検出システム、並びに指示位置検出方法 | |
| CN106851234B (zh) | 投影仪以及投影仪的控制方法 | |
| CN110463191B (zh) | 投影仪及投影仪的控制方法 | |
| US10638100B2 (en) | Projector, multi-projection system, and method for controlling projector | |
| US11832031B2 (en) | Projection system controlling method, and projector | |
| US9794471B2 (en) | Imaging device and focusing control method | |
| US20210392311A1 (en) | Evaluation method for image projection system, image projection system, and image projection control apparatus | |
| CN110324593A (zh) | 投影仪和投影仪的控制方法 | |
| US10466574B2 (en) | Image projection apparatus | |
| US12587619B2 (en) | Method of adjusting projection image, projection system, and control apparatus | |
| US20240348741A1 (en) | Control device, control method, and control program | |
| US11889238B2 (en) | Projection apparatus, projection method, and control program | |
| JPWO2019167527A1 (ja) | 投影制御装置、投影装置、投影制御方法、及び投影制御プログラム | |
| US20180276791A1 (en) | Information processing apparatus, image display method, display system, and computer readable storage medium | |
| CN115343898A (zh) | 投影系统及投射影像叠加方法 | |
| JP2015167310A (ja) | 撮像装置及び撮像方法 | |
| US10591299B2 (en) | Information processing device, information processing method, and program | |
| US11895444B2 (en) | Control device, control method, projection system, and control program | |
| US11947759B2 (en) | Projection system sharing image between projection device and display device | |
| US20230171384A1 (en) | Projection system and method of controlling projection system | |
| JP6642032B2 (ja) | プロジェクター及びプロジェクターの制御方法 | |
| US20250071243A1 (en) | Control device, moving object, control method, and control program | |
| CN108983962A (zh) | 显示装置以及显示装置的控制方法 | |
| US10860144B2 (en) | Projector and method for controlling projector | |
| CN118741062A (zh) | 投射图像的调整方法、投射系统、信息处理装置和记录介质 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22915725 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2023570822 Country of ref document: JP |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 22915725 Country of ref document: EP Kind code of ref document: A1 |