WO2022259595A1 - 介護ロボット - Google Patents
介護ロボット Download PDFInfo
- Publication number
- WO2022259595A1 WO2022259595A1 PCT/JP2022/001667 JP2022001667W WO2022259595A1 WO 2022259595 A1 WO2022259595 A1 WO 2022259595A1 JP 2022001667 W JP2022001667 W JP 2022001667W WO 2022259595 A1 WO2022259595 A1 WO 2022259595A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- robot
- care
- joint axis
- care robot
- application
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images










Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J19/00—Accessories fitted to manipulators, e.g. for monitoring, for viewing; Safety devices combined with or specially adapted for use in connection with manipulators
- B25J19/02—Sensing devices
- B25J19/021—Optical sensing devices
- B25J19/023—Optical sensing devices including video camera means
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J11/00—Manipulators not otherwise provided for
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J11/00—Manipulators not otherwise provided for
- B25J11/008—Manipulators for service tasks
- B25J11/009—Nursing, e.g. carrying sick persons, pushing wheelchairs, distributing drugs
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J5/00—Manipulators mounted on wheels or on carriages
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J5/00—Manipulators mounted on wheels or on carriages
- B25J5/007—Manipulators mounted on wheels or on carriages mounted on wheels
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/06—Program-controlled manipulators characterised by multi-articulated arms
Definitions
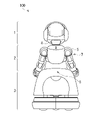
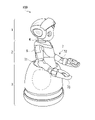
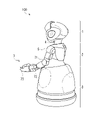
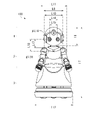
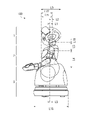
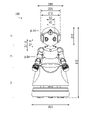
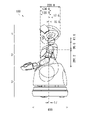
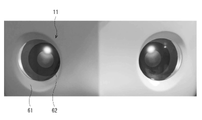
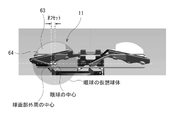
- a care robot 100 includes a head 1 having eyeballs 11 , a chest 2 , and a base 3 that supports the chest 2 .
- the lower portion of the base portion 3 is, for example, an omnidirectional mobile carriage. Thereby, the care robot 100 can move in all directions.
- the various sensors 110 include a vital sensor, a microphone, a distance image sensor, an omnidirectional distance sensor, a tactile sensor, and a force sensor. Some of the various sensors 110 are provided in the head sensor 51, the chest sensor 52, and the hand sensor 53 described above.
- the real need from the nursing care facility is to stabilize the mental state of the subject 101 of nursing care by watching over (state observation and communication) while the staff member 200 is absent.
- the nursing care robot 100 which can actively go to acquire information, watches over the nursing care target person 101 in advance and continues approaches such as greetings, voices, prompting, etc. Calm the state and try to preserve the stable state.
- the group of applications installed in the robot operating system aims to reduce the work load on the staff member 200 and further stabilize the mental state of the care recipient 101 .
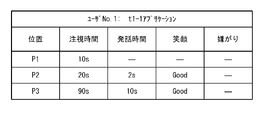
- the evaluation data includes the gaze time of the subject 101 toward the care robot 100 (the time during which the face and eyes are aligned, etc.), the utterance time of the subject 101, whether or not a smile of the subject 101 is detected, and negative reactions. The presence or absence of, etc. may be included.
- This evaluation data may be defined as an acceptability value.
- the application generating unit 323 obtains the optimum approach distance and approach that match the receptivity of each subject 101, and causes the care robot 100 to perform caregiving actions.
- the above application list is the result of consideration of needs (level of problems), functions, value to be obtained, and technical feasibility from among 50 items of applications that may be used in nursing care site work that were created in advance. , the selection is made in order of importance under the supervision of the staff member 200 .
- Active monitoring which is a basic application, (1) Differences between morning, noon, night, and midnight (2) Differences between states on bed in living room 402 (Fig. 28) and on wheelchair in living room 401 (Fig. 28) (3) Care recipient 101 Degree of dementia (4)
- Individual approaches such as how to keep a distance from the target person 101, how to approach the target person 101, greetings, and dialogue content, are optimized according to the target person 101, and can be executed through a schedule and sensing results.
- An individual approach is automatically generated for each target person 101 by the application generating unit 323 and presented to the large information terminal 310 or the small information terminal 212 .
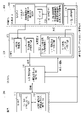
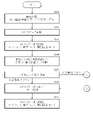
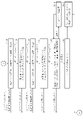
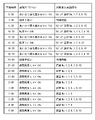
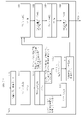
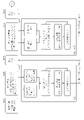
- FIG. 23 and FIG. 24 show the processing flow of an embodiment of the basic application "greeting to calm down/vital measurement".
- the positional distance and angle values shown in FIGS. 23 and 24 are representative examples, and it is important to go through the stages of long, medium, and short distances.
- Optimum values are set for each subject 101 for the above numerical values.
- the care robot 100 performs greetings by speech and motion, measures vitals, checks for negative reactions while measuring reactions, and moves between waypoints.
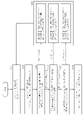
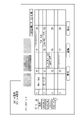
- FIG. 25 shows the flow of this sensing.
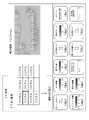
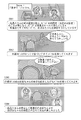
- the measured evaluation data is output as a table so that the employee 200 can confirm it, and can be displayed on a small information terminal 12 such as a tablet operated by the employee 200 (FIG. 26).
- the robot operation system collects, as evaluation data, gaze time (face and eye direction match), speech time, presence/absence of smile detection, and presence/absence of negative reaction. is output (step S207).
- the robot operation system acquires the family information of the subject 101 (step S501).
- the robot operation system prepares to know what the subject 101 wants to do (step S502).
- the target person 101 is asked to select from provided contents (photographs, etc.) output (displayed) from the application generation unit 323 of the center PC 320 to the small information terminal 130 carried by the care robot 100 .
- the robot operation system performs processing to find out what the subject 101 wants to do (step S503).
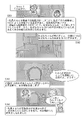
- the care robot 100 makes a conversation while looking at the photos output (displayed) on the small information terminal 130 to create a "memory talk album".
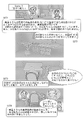
- the care robot 100 can extend its arm from the side of the table 500 and place the compact information terminal 130 in the optimal posture for the user.
- the robot operation system can capture the face of the user, who is the caller, using a camera arranged on the small information terminal 130, for example.
- the work load on the staff member 200 can be reduced, and care work can be carried out with peace of mind.
- the number of people who wish to enter facilities that have been introduced increases.
- the number of people who wish to work as nursing care staff 200 and nursing staff 200 at the introduced facility increases.
- the person 101 can be loved like a child or grandchild, and by being taken care of, the person 101 to be cared for can live with a role.
Landscapes
- Engineering & Computer Science (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Multimedia (AREA)
- Health & Medical Sciences (AREA)
- General Health & Medical Sciences (AREA)
- Nursing (AREA)
- Manipulator (AREA)
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US18/565,642 US12454062B2 (en) | 2021-06-10 | 2022-01-18 | Nursing care robot |
| JP2023527478A JP7872905B2 (ja) | 2021-06-10 | 2022-01-18 | 介護ロボット |
| CN202280039626.6A CN117412839A (zh) | 2021-06-10 | 2022-01-18 | 护理机器人 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021-097442 | 2021-06-10 | ||
| JP2021097442 | 2021-06-10 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022259595A1 true WO2022259595A1 (ja) | 2022-12-15 |
Family
ID=84425612
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/001667 Ceased WO2022259595A1 (ja) | 2021-06-10 | 2022-01-18 | 介護ロボット |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US12454062B2 (cg-RX-API-DMAC7.html) |
| JP (1) | JP7872905B2 (cg-RX-API-DMAC7.html) |
| CN (1) | CN117412839A (cg-RX-API-DMAC7.html) |
| WO (1) | WO2022259595A1 (cg-RX-API-DMAC7.html) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2024211611A1 (en) * | 2023-04-05 | 2024-10-10 | Sony Interactive Entertainment Inc. | Reproducing fast eye movement using imaging of robot with limited actuator speed |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002307338A (ja) * | 2001-04-18 | 2002-10-23 | Nippon Telegr & Teleph Corp <Ntt> | 動作型存在情報伝達装置およびその制御方法 |
| JP2018124399A (ja) * | 2017-01-31 | 2018-08-09 | 富士フイルム株式会社 | ディスプレイ及びロボット |
| JP2019055463A (ja) * | 2017-09-21 | 2019-04-11 | パナソニック株式会社 | 移動体 |
| JP2019089197A (ja) * | 2016-09-08 | 2019-06-13 | Groove X株式会社 | 自然な距離感を保つ自律行動型ロボットおよびプログラム |
| JP2019130610A (ja) * | 2018-01-31 | 2019-08-08 | トヨタ自動車株式会社 | コミュニケーションロボットおよびその制御プログラム |
| JP6588624B2 (ja) * | 2016-04-05 | 2019-10-09 | 株式会社日立製作所 | ヒューマノイドロボット |
Family Cites Families (18)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP4252721B2 (ja) * | 2000-11-17 | 2009-04-08 | 本田技研工業株式会社 | 二足歩行ロボット |
| WO2004082900A1 (ja) * | 2003-03-23 | 2004-09-30 | Sony Corporation | ロボット装置及びその制御方法 |
| JP2009113135A (ja) * | 2007-11-05 | 2009-05-28 | Hitachi Ltd | 2足型移動機構 |
| WO2009125648A1 (ja) | 2008-04-07 | 2009-10-15 | 株式会社安川電機 | 多関節ロボットおよびシステム |
| JP5499647B2 (ja) | 2009-11-10 | 2014-05-21 | 株式会社安川電機 | ロボット及びロボットシステム |
| KR101929451B1 (ko) * | 2012-02-03 | 2018-12-14 | 삼성전자주식회사 | 로봇의 제어 장치 및 방법 |
| US20140039675A1 (en) * | 2012-08-03 | 2014-02-06 | Nimer Mohammed Ead | Instructional humanoid robot apparatus and a method thereof |
| US9132359B2 (en) * | 2013-10-30 | 2015-09-15 | Razor Usa Llc | Kart with movable visual effect |
| US9592603B2 (en) * | 2014-12-01 | 2017-03-14 | Spin Master Ltd. | Reconfigurable robotic system |
| JP6519560B2 (ja) * | 2016-09-23 | 2019-05-29 | カシオ計算機株式会社 | ロボット、ロボットの作動方法及びプログラム |
| CN106422349A (zh) * | 2016-11-09 | 2017-02-22 | 遵义市斑寅科技有限公司 | 一种多功能机器人玩具 |
| JP2019005842A (ja) * | 2017-06-23 | 2019-01-17 | カシオ計算機株式会社 | ロボット、ロボットの制御方法及びプログラム |
| DE112018005034B4 (de) * | 2017-09-11 | 2022-05-12 | Groove X, Inc. | Autonom handelnder Roboter, der den Begleiter anblickt |
| JP7020159B2 (ja) * | 2018-02-07 | 2022-02-16 | トヨタ自動車株式会社 | コミュニケーション装置およびその制御プログラム |
| WO2019246236A1 (en) * | 2018-06-19 | 2019-12-26 | Realbotix, Llc | Interchangeable face having magnetically adjustable facial contour and integral eyelids |
| JP7579958B2 (ja) * | 2021-02-18 | 2024-11-08 | 株式会社日立ハイテク | 移動型ロボット |
| CN118632733A (zh) * | 2022-02-02 | 2024-09-10 | 日东电工株式会社 | 机器人 |
| US20240091964A1 (en) * | 2022-09-16 | 2024-03-21 | Sarcos Corp. | Multidirectional Sensing Array for Robot Perception |
-
2022
- 2022-01-18 JP JP2023527478A patent/JP7872905B2/ja active Active
- 2022-01-18 CN CN202280039626.6A patent/CN117412839A/zh not_active Withdrawn
- 2022-01-18 US US18/565,642 patent/US12454062B2/en active Active
- 2022-01-18 WO PCT/JP2022/001667 patent/WO2022259595A1/ja not_active Ceased
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002307338A (ja) * | 2001-04-18 | 2002-10-23 | Nippon Telegr & Teleph Corp <Ntt> | 動作型存在情報伝達装置およびその制御方法 |
| JP6588624B2 (ja) * | 2016-04-05 | 2019-10-09 | 株式会社日立製作所 | ヒューマノイドロボット |
| JP2019089197A (ja) * | 2016-09-08 | 2019-06-13 | Groove X株式会社 | 自然な距離感を保つ自律行動型ロボットおよびプログラム |
| JP2018124399A (ja) * | 2017-01-31 | 2018-08-09 | 富士フイルム株式会社 | ディスプレイ及びロボット |
| JP2019055463A (ja) * | 2017-09-21 | 2019-04-11 | パナソニック株式会社 | 移動体 |
| JP2019130610A (ja) * | 2018-01-31 | 2019-08-08 | トヨタ自動車株式会社 | コミュニケーションロボットおよびその制御プログラム |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2024211611A1 (en) * | 2023-04-05 | 2024-10-10 | Sony Interactive Entertainment Inc. | Reproducing fast eye movement using imaging of robot with limited actuator speed |
| US12280508B2 (en) | 2023-04-05 | 2025-04-22 | Sony Interactive Entertainment Inc. | Reproducing fast eye movement using imaging of robot with limited actuator speed |
Also Published As
| Publication number | Publication date |
|---|---|
| US20240261979A1 (en) | 2024-08-08 |
| US12454062B2 (en) | 2025-10-28 |
| JP7872905B2 (ja) | 2026-06-11 |
| CN117412839A (zh) | 2024-01-16 |
| JPWO2022259595A1 (cg-RX-API-DMAC7.html) | 2022-12-15 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| WO2022259596A1 (ja) | ロボット運用システム | |
| JP6215087B2 (ja) | 移動ロボットを含むロボットシステムにより実行される方法 | |
| JP2024096291A (ja) | ロボット、プログラム及び方法 | |
| JP7548621B2 (ja) | 日常生活を記録する自律行動型ロボット | |
| Hornecker et al. | The interactive enactment of care technologies and its implications for human-robot-interaction in care | |
| Louie et al. | A focus group study on the design considerations and impressions of a socially assistive robot for long-term care | |
| US10405745B2 (en) | Human socializable entity for improving digital health care delivery | |
| CN109526208A (zh) | 活动量受控制的行为自主型机器人 | |
| US20200077800A1 (en) | Microclimate control systems and methods | |
| CN117666867A (zh) | 机器人 | |
| JP2024055866A (ja) | 内部状態または外部環境に応じて自律的に行動選択するロボット | |
| CN109690435A (zh) | 保持自然的距离感的行为自主型机器人 | |
| CN109475464A (zh) | 按摩机 | |
| Bedaf et al. | Robots supporting care for elderly people | |
| US12454062B2 (en) | Nursing care robot | |
| JP2020089947A (ja) | 情報処理装置、情報処理方法及びプログラム | |
| JP7189434B2 (ja) | 空間制御システム | |
| WO2024190301A1 (en) | Information processing device and nursing care robot control method | |
| US12468556B2 (en) | Intermediary device for offloading processing operations for an artificial-reality system and for enabling interactions and input paradigms, and systems and methods of use thereof | |
| US20250312220A1 (en) | Nursing care robot, method for controlling nursing care robot, and information processing device | |
| JP2022074047A (ja) | 対話型リマインダ・コンパニオン | |
| US20260089459A1 (en) | Systems and methods for integrating spatial audio with artificial intelligence assistants | |
| Westermann | Robotic presences: encounters with artificial social companionship and embodied representation | |
| Stegner et al. | Factors that Affect Personalization of Robots for Older Adults | |
| Choi | A study of human-robot interaction with an assistive robot to help people with severe motor impairments |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22819786 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2023527478 Country of ref document: JP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 18565642 Country of ref document: US |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 202280039626.6 Country of ref document: CN |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 22819786 Country of ref document: EP Kind code of ref document: A1 |
|
| WWG | Wipo information: grant in national office |
Ref document number: 18565642 Country of ref document: US |