WO2021024589A1 - モビリティ制御システム、方法、および、プログラム - Google Patents
モビリティ制御システム、方法、および、プログラム Download PDFInfo
- Publication number
- WO2021024589A1 WO2021024589A1 PCT/JP2020/021377 JP2020021377W WO2021024589A1 WO 2021024589 A1 WO2021024589 A1 WO 2021024589A1 JP 2020021377 W JP2020021377 W JP 2020021377W WO 2021024589 A1 WO2021024589 A1 WO 2021024589A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- software
- mobility
- status
- state
- update
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F8/00—Arrangements for software engineering
- G06F8/60—Software deployment
- G06F8/65—Updates
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F21/00—Security arrangements for protecting computers, components thereof, programs or data against unauthorised activity
- G06F21/50—Monitoring users, programs or devices to maintain the integrity of platforms, e.g. of processors, firmware or operating systems
- G06F21/57—Certifying or maintaining trusted computer platforms, e.g. secure boots or power-downs, version controls, system software checks, secure updates or assessing vulnerabilities
- G06F21/577—Assessing vulnerabilities and evaluating computer system security
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F8/00—Arrangements for software engineering
- G06F8/70—Software maintenance or management
- G06F8/71—Version control; Configuration management
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F2221/00—Indexing scheme relating to security arrangements for protecting computers, components thereof, programs or data against unauthorised activity
- G06F2221/03—Indexing scheme relating to G06F21/50, monitoring users, programs or devices to maintain the integrity of platforms
- G06F2221/033—Test or assess software
Definitions
- the present invention relates to a mobility control system, a mobility control method, and a mobility control program that perform control according to the situation of mobility equipped with software.
- mobility is defined as meaning means of transportation (for example, a vehicle such as a vehicle).
- a lot of software is used to control mobility. For example, various processes such as a process for realizing the above communication function, a process for controlling various functions of mobility, and a process for detecting an abnormality are performed by software. Is realized using.
- Patent Document 1 describes a system that takes measures when an abnormality occurs in communication data in an in-vehicle system.
- the system described in Patent Document 1 collects information for determining the state from each information processing device in the in-vehicle system when an abnormality of communication data occurs in the in-vehicle system, and causes a security abnormality and a safety abnormality. Identify the presence or absence of occurrence for each. Then, the system determines the action to be taken for the abnormality and notifies each information processing apparatus.
- Patent Document 2 describes a system for diagnosing abnormalities in a vehicle in real time by transmitting diagnostic target data to a center device.
- the diagnostic target data detected by the diagnostic vehicle device is transmitted to the center device, it is determined whether or not the center device is a rare event, and whether or not the diagnostic vehicle is abnormal based on the determination result. And send the diagnosis result to the diagnostic vehicle device.
- an object of the present invention is to provide a mobility control system, a mobility control method, and a mobility control program that can appropriately control the mobility according to the state of software used for controlling the mobility.
- the mobility control system is a mobility control system that is mounted on the mobility to be controlled and controls according to the state of the mobility, and is a software state detection unit that detects the state of software that controls the mobility and software. It is equipped with a control unit that controls to limit the operating function of mobility based on the state of the software, the software state detection unit detects the version information or update status of the software as the software status, and the control unit controls the software. It is characterized in that the function to be restricted is determined based on the state of.
- the mobility control method according to the present invention is a mobility control method that performs control according to a target mobility state, detects software version information or update status as software state, and is based on the software state. It is characterized by performing control that limits the operating functions of mobility.
- the mobility control program according to the present invention is a mobility control program applied to a computer mounted on the mobility to be controlled and performing control according to the state of the mobility, and the computer detects the state of software that controls the mobility.
- the software status detection process to be performed and the control process that controls to limit the operating function of mobility based on the software status are executed, and the software status detection process is used as the software version information or update status. It is characterized in that the function to be restricted is determined based on the state of the software in the control process.
- the mobility can be appropriately controlled according to the state of the software used for controlling the mobility.
- FIG. 1 is a block diagram showing a configuration example of an embodiment of the mobility control system according to the present invention.
- the mobility control system 100 of the present embodiment includes a communication device 10, a unit 20, a software state detection unit 30, a control unit 40, and an input / output device 50.
- the mobility control system 100 is a system that is mounted on the mobility 300 to be controlled and takes measures according to the state of the mobility 300.
- a specific example of the mobility 300 is a connected car.
- the software used for the communication device 10 and the unit 20 can be updated by OTA (Over the Air).
- OTA Over the Air
- various functions of an autonomous vehicle using GPS (Global Positioning System), road installation equipment, the Internet, etc. will be described as specific examples.
- the mobility 300 is not limited to a vehicle, and may be, for example, a train or an aircraft.
- the mobility control system 100 communicates with the security center server 210 in the external security center 200 via the communication device 10.
- the security center server 210 transmits information necessary for controlling mobility and information related to software to the mobility control system 100.
- the communication device 10 is a device that communicates with the security center server 210 or an arbitrary external server (not shown).
- the mode of the communication device 10 is arbitrary, and is realized by, for example, a communication device equipped with a module dedicated to the vehicle.
- the communication device 10 may notify the software state detection unit 30, which will be described later, of the communication status and software information notified from an external device.
- the unit 20 is a unit that detects and controls various states of mobility, and is realized by, for example, various electronic control units. Although only one unit 20 is shown in FIG. 1, the number of units 20 is not limited to one, and may be two or more.
- the mobility control system 100 includes a plurality of units 20 according to the control target.
- control targets include an engine, a brake, a meter, a car navigation system, and an airbag.
- the unit 20 of the present embodiment may be realized by a computer processor (for example, CPU (Central Processing Unit), GPU (Graphics Processing Unit)) that operates according to software for performing various controls of mobility.
- a computer processor for example, CPU (Central Processing Unit), GPU (Graphics Processing Unit)
- CPU Central Processing Unit
- GPU Graphics Processing Unit
- Types of software include software that controls telematics, software that controls driving, software that controls automatic driving, and so on.
- Examples of control targets related to driving include engines, brakes, and steering wheels.
- control targets related to automatic driving include cameras, inter-vehicle sensors, GPS, and the like.
- the above-mentioned classification of software types is an example, and the classification may be individually defined according to the software.
- the software that controls the telematics described above is usually allowed to be updated during manual driving or restricted automatic driving (for example, automatic driving in a range that does not use the communication function). Also, the software that controls driving is usually not allowed to be updated while driving. In addition, the software that controls automatic driving is allowed to be updated during manual driving.
- the software state detection unit 30 detects the state of the software that controls mobility. Specifically, the software state detection unit 30 detects the state of software used in the communication device 10 and the unit 20 that controls various states of mobility. The software state detection unit 30 may detect the state of the software by periodically inquiring the unit 20 about the state, or may detect the state of the software based on the situation notified from the unit 20. Further, the software state detection unit 30 may detect the state of the software when the external device (for example, the security center server 210) notifies the information about the software (for example, update information).
- the external device for example, the security center server 210
- the software state detection unit 30 detects the version information of the software or the update status in the mobility control system 100 as the state of the software.
- Software update status includes statuses such as currently being updated, waiting for an update, and failing to update.
- the software state detection unit 30 detects whether or not the target software is the latest as software version information. Further, when the software is not the latest (old version), the software state detection unit 30 may further detect the presence or absence of a vulnerability in the software.
- the software state detection unit 30 periodically sends update information of software used by the mobility control system 100 and information indicating the presence or absence of vulnerabilities to an external device (for example, security center server 210) via the communication device 10. You may inquire, or you may receive update information from the software manufacturer on an irregular basis. Then, the software state detection unit 30 may detect the state of the software currently being used based on the update information of the software obtained from the external device or the information indicating the presence or absence of the vulnerability.
- the control unit 40 controls to limit the operating function of the mobility 300 based on the software state detected by the software state detection unit 30. Specifically, the control unit 40 determines a function to be restricted based on the state of the software, and performs various controls on the determined function.
- control unit 40 When it is detected that the software is not the latest version, the control unit 40 notifies the user of the recommendation of updating to the latest version. If the software is vulnerable, the control unit 40 notifies the user to strongly recommend updating to the latest version, and further limits the functions according to the location of the vulnerabilities. Control may be performed. In this way, by limiting the functions according to the location of the vulnerability, only the target functions are restricted while suppressing the influence on other functions operated by software that has vulnerabilities in some functions. Will be possible.
- control unit 40 may limit the functions according to the location of the vulnerability in the same manner as the function restrictions performed during the software update.
- the control unit 40 may, for example, control the input / output device 50, which will be described later, to output that the software needs to be updated.
- control unit 40 controls to limit the functions according to the update location.
- software that controls telematics uses communication functions to send and receive various information necessary for driving. Therefore, when the software that controls telematics is being updated, the control unit 40 may perform control that limits the functions of the communication device.
- control unit 40 may perform control that limits various functions so that the driver cannot drive. In this case, the control unit 40 may control so that the software cannot be updated until the vehicle is stopped.
- control unit 40 may perform control for limiting the function for performing the automatic operation and may perform control for performing the manual operation.
- control unit 40 controls to notify the user that the mobility operation function (operation mode) will change due to the update, and the software to be updated is vulnerable. Control is performed according to the presence or absence of sex. Specifically, when it is found that the software waiting for update has a vulnerability, the control unit 40 controls to limit the function according to the location of the vulnerability.
- control unit 40 controls the user to notify that the update has failed and to urge the user to re-update, as in the case of waiting for the update. To control. That is, the control unit 40 performs control according to the presence or absence of vulnerabilities in the software to be updated, in addition to the above notification.
- control unit 40 may notify the user whether or not to automatically start the update.
- the input / output device 50 is a device that performs input / output processing between the operator of the mobility 300 and the mobility control system 100.
- the input / output device 50 is realized by, for example, IVI (in-vehicle infotainment).
- the input / output device 50 may output the software update status and the control content by the control unit 40 in response to an instruction from the control unit 40.
- the software state detection unit 30 and the control unit 40 are realized by a computer processor (for example, a CPU (Central Processing Unit) or a GPU (Graphics Processing Unit)) that operates according to a program (mobility control program).
- a computer processor for example, a CPU (Central Processing Unit) or a GPU (Graphics Processing Unit)
- a program mobility control program
- the program may be stored in a storage unit (not shown) included in the mobility control system 100, and the processor may read the program and operate as the software state detection unit 30 and the control unit 40 according to the program.
- the function of the mobility control system 100 may be provided in the SaaS (Software as a Service) format.
- the software state detection unit 30 and the control unit 40 may each be realized by dedicated hardware. Further, a part or all of each component of each device may be realized by a general-purpose or dedicated circuit (circuitry), a processor, or a combination thereof. These may be composed of a single chip or may be composed of a plurality of chips connected via a bus. A part or all of each component of each device may be realized by a combination of the above-mentioned circuit or the like and a program.
- the plurality of information processing devices and circuits may be centrally arranged. It may be distributed.
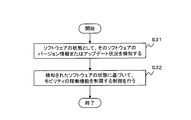
- FIG. 2 is a flowchart showing an operation example of the mobility control system 100 of the present embodiment.
- the software state detection unit 30 detects the version information or update status of the software as the state of the software (step S31).
- the control unit 40 controls to limit the operating function of the mobility based on the detected software state (step S32).
- the software state detection unit 30 detects the software version information or the update status as the software state, and the control unit 40 operates the mobility operation function based on the software state. Control to limit. Therefore, the mobility can be appropriately controlled according to the state of the software used for controlling the mobility.
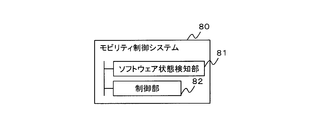
- FIG. 3 is a block diagram showing an outline of the mobility control system according to the present invention.
- the mobility control system 80 according to the present invention is a mobility control system (for example, a mobility control system 100) that is mounted on a controlled mobility (for example, a mobility 300) and performs control according to the state of the mobility.
- a software state detection unit 81 for example, software state detection unit 30
- a control unit 82 for example, control unit 40
- the software state detection unit 81 detects the version information or update status of the software as the software state, and the control unit 82 determines the function to limit based on the software state.
- the mobility can be appropriately controlled according to the state of the software used for controlling the mobility.
- the software status detection unit 81 detects the software update status as the software status, and the control unit 82 performs a function according to the update location when the software status detection unit 81 detects the status of being updated. Control may be performed to limit. With such a configuration, it is possible to suppress changes in functions affected by the update in advance.
- the software state detection unit 81 may detect the presence or absence of software vulnerabilities as the software state, and the control unit 82 may perform control to limit the functions according to the location of the vulnerabilities. With such a configuration, it becomes possible to suppress the occurrence of unexpected behavior based on a function having a vulnerability.
- the software state detection unit 81 detects that the software is waiting for a software update or has failed to update the software, and the control unit 82 is included in the software waiting for the update or the software that has failed to update. Control may be performed to limit the functions according to the location of the vulnerability. With such a configuration, it is possible to suppress unexpected behavior based on a function having a vulnerability that may occur before the update is performed.
- the mobility may be a connected car that automatically drives.
- the software state detection unit 81 may detect the state of the software currently in use based on the update information of the software obtained from the external device or the information indicating the presence or absence of the vulnerability.
- the software state detection unit 81 detects the software update status as the software status, and the control unit 82 performs automatic operation when the software status detection unit 81 detects the status during the update. You may perform control to limit the function for the purpose. With such a configuration, it becomes possible to suppress unexpected movements on automatic driving.
Landscapes
- Engineering & Computer Science (AREA)
- General Engineering & Computer Science (AREA)
- Software Systems (AREA)
- Theoretical Computer Science (AREA)
- Computer Security & Cryptography (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Computer Hardware Design (AREA)
- Computing Systems (AREA)
- Stored Programmes (AREA)
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US17/632,366 US20220283798A1 (en) | 2019-08-06 | 2020-05-29 | Mobility control system, method, and program |
| JP2021537593A JP7310891B2 (ja) | 2019-08-06 | 2020-05-29 | モビリティ制御システム、方法、および、プログラム |
| JP2023105592A JP7605251B2 (ja) | 2019-08-06 | 2023-06-28 | モビリティ制御システム、方法、および、プログラム |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019-144749 | 2019-08-06 | ||
| JP2019144749 | 2019-08-06 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2021024589A1 true WO2021024589A1 (ja) | 2021-02-11 |
Family
ID=74502496
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2020/021377 Ceased WO2021024589A1 (ja) | 2019-08-06 | 2020-05-29 | モビリティ制御システム、方法、および、プログラム |
Country Status (3)
| Country | Link |
|---|---|
| US (1) | US20220283798A1 (cg-RX-API-DMAC7.html) |
| JP (2) | JP7310891B2 (cg-RX-API-DMAC7.html) |
| WO (1) | WO2021024589A1 (cg-RX-API-DMAC7.html) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPWO2023068019A1 (cg-RX-API-DMAC7.html) * | 2021-10-20 | 2023-04-27 | ||
| DE102022132651A1 (de) | 2021-12-16 | 2023-06-22 | Denso Corporation | Elektronische Steuervorrichtung |
| JP2024024553A (ja) * | 2022-08-09 | 2024-02-22 | 株式会社デンソー | 更新制御装置、更新制御方法、及び更新制御プログラム |
Families Citing this family (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20260089627A (ko) * | 2023-12-14 | 2026-06-15 | 엘지전자 주식회사 | 신호처리장치, 이를 구비하는 차량용 제어 장치 및 그 동작방법 |
| US20260039710A1 (en) * | 2024-08-05 | 2026-02-05 | Dell Products L.P. | Size-based data file prioritization for data package transfers |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2018163613A (ja) * | 2017-03-27 | 2018-10-18 | パナソニックIpマネジメント株式会社 | 電子機器、プログラム更新方法およびコンピュータプログラム |
| JP2019036251A (ja) * | 2017-08-21 | 2019-03-07 | 株式会社東芝 | 更新制御装置、ソフトウェア更新システムおよび更新制御方法 |
| JP2019071572A (ja) * | 2017-10-10 | 2019-05-09 | ローベルト ボッシュ ゲゼルシャフト ミット ベシュレンクテル ハフツング | 制御装置及び制御方法 |
Family Cites Families (23)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US9003395B2 (en) * | 2012-08-10 | 2015-04-07 | Adobe Systems Incorporated | Directing plug-in updates for a software application to a target audience using manifest parameters |
| US9648023B2 (en) * | 2015-01-05 | 2017-05-09 | Movimento Group | Vehicle module update, protection and diagnostics |
| JP2016218932A (ja) | 2015-05-26 | 2016-12-22 | 京セラ株式会社 | ソフトウェア更新装置およびソフトウェア更新システム |
| JP6524501B2 (ja) * | 2015-06-11 | 2019-06-05 | パナソニックIpマネジメント株式会社 | 車両制御装置、車両制御方法および車両制御プログラム |
| KR101704567B1 (ko) * | 2015-08-27 | 2017-02-08 | 현대자동차주식회사 | 차량 연동 앱 관리 방법, 장치 및 시스템 |
| JP6365572B2 (ja) | 2016-03-14 | 2018-08-01 | トヨタ自動車株式会社 | 車両用のソフトウェア管理システム、管理サーバ及び車両 |
| JP6805559B2 (ja) * | 2016-06-09 | 2020-12-23 | 株式会社デンソー | リプログマスタ |
| JP6658409B2 (ja) | 2016-09-02 | 2020-03-04 | 株式会社オートネットワーク技術研究所 | 車載更新システム、車載更新装置及び通信装置の更新方法 |
| JP6697357B2 (ja) * | 2016-09-15 | 2020-05-20 | 株式会社日立製作所 | ソフトウェア更新システム |
| DE112016007309T5 (de) * | 2016-10-03 | 2019-07-04 | Mitsubishi Electric Corporation | Informationsausgabesteuervorrichtung und Informationsausgabesteuerverfahren |
| JP6760813B2 (ja) * | 2016-10-14 | 2020-09-23 | 日立オートモティブシステムズ株式会社 | ソフトウェア更新装置、ソフトウェア更新方法、ソフトウェア更新システム |
| JP6270965B1 (ja) * | 2016-11-16 | 2018-01-31 | 三菱電機株式会社 | プログラムの更新制御システムおよびプログラムの更新制御方法 |
| CN110753906B (zh) * | 2017-06-13 | 2023-08-08 | 住友电气工业株式会社 | 更新控制装置、控制方法以及计算机程序 |
| JP6755219B2 (ja) * | 2017-07-12 | 2020-09-16 | クラリオン株式会社 | 情報配信システム及び車載装置 |
| US10289404B2 (en) * | 2017-07-25 | 2019-05-14 | Aurora Labs Ltd. | Detecting anomalies using real-time ECU processing activity |
| JP6940365B2 (ja) | 2017-10-12 | 2021-09-29 | 日立Astemo株式会社 | 情報更新装置 |
| JP7311245B2 (ja) * | 2018-03-07 | 2023-07-19 | トヨタ自動車株式会社 | マスタ装置、マスタ、制御方法、プログラム及び車両 |
| JP7102922B2 (ja) * | 2018-05-11 | 2022-07-20 | 株式会社アイシン | 車両盗難防止装置 |
| WO2020032121A1 (ja) * | 2018-08-10 | 2020-02-13 | 株式会社デンソー | 車両用マスタ装置、更新データの検証方法及び更新データの検証プログラム |
| JP7192415B2 (ja) * | 2018-11-06 | 2022-12-20 | 株式会社オートネットワーク技術研究所 | プログラム更新システム及び更新処理プログラム |
| US11032716B2 (en) * | 2018-11-30 | 2021-06-08 | Blackberry Limited | Secure communication for machine to machine connections |
| JP7564819B2 (ja) * | 2019-03-25 | 2024-10-09 | オーロラ ラブズ リミテッド | コード行挙動および関係モデルの発生ならびに署名 |
| DE112020002261T5 (de) * | 2019-05-07 | 2022-02-17 | Sony Semiconductor Solutions Corporation | Datenverarbeitungsvorrichtung, Bewegungsvorrichtung und Verfahren sowie Programm |
-
2020
- 2020-05-29 US US17/632,366 patent/US20220283798A1/en not_active Abandoned
- 2020-05-29 WO PCT/JP2020/021377 patent/WO2021024589A1/ja not_active Ceased
- 2020-05-29 JP JP2021537593A patent/JP7310891B2/ja active Active
-
2023
- 2023-06-28 JP JP2023105592A patent/JP7605251B2/ja active Active
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2018163613A (ja) * | 2017-03-27 | 2018-10-18 | パナソニックIpマネジメント株式会社 | 電子機器、プログラム更新方法およびコンピュータプログラム |
| JP2019036251A (ja) * | 2017-08-21 | 2019-03-07 | 株式会社東芝 | 更新制御装置、ソフトウェア更新システムおよび更新制御方法 |
| JP2019071572A (ja) * | 2017-10-10 | 2019-05-09 | ローベルト ボッシュ ゲゼルシャフト ミット ベシュレンクテル ハフツング | 制御装置及び制御方法 |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPWO2023068019A1 (cg-RX-API-DMAC7.html) * | 2021-10-20 | 2023-04-27 | ||
| WO2023068019A1 (ja) * | 2021-10-20 | 2023-04-27 | 株式会社小糸製作所 | 車両システム |
| JP7863573B2 (ja) | 2021-10-20 | 2026-05-21 | 株式会社小糸製作所 | 車両システム |
| DE102022132651A1 (de) | 2021-12-16 | 2023-06-22 | Denso Corporation | Elektronische Steuervorrichtung |
| JP2024024553A (ja) * | 2022-08-09 | 2024-02-22 | 株式会社デンソー | 更新制御装置、更新制御方法、及び更新制御プログラム |
| JP7771892B2 (ja) | 2022-08-09 | 2025-11-18 | 株式会社デンソー | 更新制御装置、更新制御方法、及び更新制御プログラム |
Also Published As
| Publication number | Publication date |
|---|---|
| JP7310891B2 (ja) | 2023-07-19 |
| JP2023115229A (ja) | 2023-08-18 |
| JP7605251B2 (ja) | 2024-12-24 |
| JPWO2021024589A1 (cg-RX-API-DMAC7.html) | 2021-02-11 |
| US20220283798A1 (en) | 2022-09-08 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7605251B2 (ja) | モビリティ制御システム、方法、および、プログラム | |
| US20200195472A1 (en) | Security device, network system, and fraud detection method | |
| EP3885227B1 (en) | Apparatus for controlling autonomous driving of a vehicle, system having the same and method thereof | |
| CN112537318B (zh) | 用于远程控制机动车的方法 | |
| CN111586625B (zh) | 控制器和自动驾驶车辆 | |
| US20170270291A1 (en) | Information processing system | |
| CN110268681A (zh) | 车载网关装置和通信切断方法 | |
| US20210086792A1 (en) | Method of assisting a motor vehicle | |
| US20220250655A1 (en) | Mobility control system, method, and program | |
| US20230267776A1 (en) | Vehicle monitoring program, vehicle-mounted device, and vehicle monitoring method | |
| CN103857575A (zh) | 用于运行车辆的驾驶员辅助系统的设备及方法 | |
| EP3090911A1 (en) | Apparatus for warning of occurrence of error of device | |
| US20240101054A1 (en) | In-vehicle device and method for starting the same | |
| US20250150485A1 (en) | Information provision method and information processing device | |
| WO2014000284A1 (en) | Method and apparatus for uniform access of onboard devices | |
| JP6441380B2 (ja) | 車載用変速機制御装置 | |
| JP2021061516A (ja) | 車両遠隔操作装置 | |
| JP7596162B2 (ja) | 整合性レベルを有する位置決めデータを提供するテレマティクス制御エンティティ | |
| JP7708316B2 (ja) | 車載システム、電子制御装置、アクセス認可ポリシー更新方法、及びプログラム | |
| US20250178617A1 (en) | In-vehicle electronic device | |
| EP4196859B1 (en) | Autonomous safety rider | |
| JP7122195B2 (ja) | 情報処理装置、情報処理方法および情報処理プログラム | |
| JP2019125947A (ja) | 監視装置、監視方法及びプログラム | |
| US20200104114A1 (en) | Information processing apparatus, computer program product, and information processing system | |
| US20250094206A1 (en) | Monitoring device and monitoring method |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20849963 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2021537593 Country of ref document: JP Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 20849963 Country of ref document: EP Kind code of ref document: A1 |