EP4545710A1 - Work machine, system including work machine, and method for controlling work machine - Google Patents
Work machine, system including work machine, and method for controlling work machine Download PDFInfo
- Publication number
- EP4545710A1 EP4545710A1 EP23862982.8A EP23862982A EP4545710A1 EP 4545710 A1 EP4545710 A1 EP 4545710A1 EP 23862982 A EP23862982 A EP 23862982A EP 4545710 A1 EP4545710 A1 EP 4545710A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- load
- work implement
- bucket
- work machine
- move
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images


Classifications
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F3/00—Dredgers; Soil-shifting machines
- E02F3/04—Dredgers; Soil-shifting machines mechanically-driven
- E02F3/28—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets
- E02F3/36—Component parts
- E02F3/42—Drives for dippers, buckets, dipper-arms or bucket-arms
- E02F3/43—Control of dipper or bucket position; Control of sequence of drive operations
- E02F3/431—Control of dipper or bucket position; Control of sequence of drive operations for bucket-arms, front-end loaders, dumpers or the like
- E02F3/434—Control of dipper or bucket position; Control of sequence of drive operations for bucket-arms, front-end loaders, dumpers or the like providing automatic sequences of movements, e.g. automatic dumping or loading, automatic return-to-dig
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/08—Superstructures; Supports for superstructures
- E02F9/0841—Articulated frame, i.e. having at least one pivot point between two travelling gear units
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/20—Drives; Control devices
- E02F9/2025—Particular purposes of control systems not otherwise provided for
- E02F9/205—Remotely operated machines, e.g. unmanned vehicles
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/26—Indicating devices
- E02F9/261—Surveying the work-site to be treated
- E02F9/262—Surveying the work-site to be treated with follow-up actions to control the work tool, e.g. controller
Definitions
- the present disclosure relates to a work machine, a system including the work machine, and a method for controlling the work machine.
- WO2016/152994 discloses control to move a boom and a bucket to a target position that is determined depending on a distance for which a wheel loader has traveled.
- the loading work When loading into a load container such as a vessel of a dump truck is performed by a work machine such as a wheel loader, the loading work is usually performed multiple times. When the amount of loads loaded onto the dump truck by the loading work performed multiple times reaches the load capacity of the dump truck, loads may spill out while the dump truck is traveling, if the loading state (load condition) of the loaded loads is inappropriate.
- the present disclosure proposes a work machine, a system including the work machine, and a method for controlling the work machine that enable appropriate loading into a load container.
- a work machine and a system including the work machine according to an aspect of the present disclosure each include: a main body, a work implement, a work implement actuator, and a controller.
- the work implement is attached to the main body and loads a load into a load container.
- the work implement actuator drives the work implement with respect to the main body.
- the controller commands the work implement actuator to drive, based on a detected value of a position of the work implement and a detected value of a position of the load container with respect to the work machine.
- the controller acquires information about a loading status of a load in the load container, determines whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load, and operates, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- a method for controlling a work machine includes: acquiring information about a loading status of a load in a load container; determining whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load; and operating, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- the work machine a system including the work machine, and a method for controlling the work machine according to the present disclosure enable appropriate loading into the load container.
- a wheel loader 1 is described as one example of the work machine.
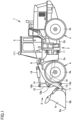
- Fig. 1 is a side view of wheel loader 1 as one example of the work machine.
- wheel loader 1 includes a vehicular body frame 2, a work implement 3, a travel device 4, and a cab 5.
- the vehicular body of wheel loader 1 is made up of vehicular body frame 2 and cab 5, for example.
- work implement 3 and travel device 4 are attached to the vehicular body of wheel loader 1, work implement 3 and travel device 4 are attached.
- the main body of wheel loader 1 includes a vehicular body and travel device 4.
- Travel device 4 causes the vehicular body of wheel loader 1 to travel, and includes running wheels 4a and 4b.
- Wheel loader 1 is a wheeled vehicle including running wheels 4a and 4b serving as traveling rotary bodies on both sides of the vehicular body in the left-right direction. Wheel loader 1 is capable of being self-propelled by rotationally driving running wheels 4a and 4b, and performing desired work using work implement 3.
- Travel device 4 corresponds to one example of "travel unit. "
- front-rear direction of wheel loader 1 The direction in which wheel loader 1 travels straight is herein referred to as front-rear direction of wheel loader 1.
- front-rear direction of wheel loader 1 the side where work implement 3 is located, with respect to vehicular body frame 2, is defined as front direction, and the side opposite to the front direction is defined as rear direction.
- the left-right direction of wheel loader 1 is a direction orthogonal to the front-rear direction as seen in a plan view of wheel loader 1 on a flat ground.
- the right side and the left side in the left-right direction, with respect to the front direction, are right direction and left direction, respectively.
- the top-bottom direction of wheel loader 1 is a direction orthogonal to a plane defined by the front-rear direction and the left-right direction. In the top-bottom direction, the side where the ground is located is the lower side, and the side where the sky is located is the upper side.
- Vehicular body frame 2 includes a front frame 2a and a rear frame 2b. Front frame 2a is disposed frontward with respect to rear frame 2b. Front frame 2a and rear frame 2b are attached to each other in such a manner that they can swing in the left-right direction.
- a pair of steering cylinders 11 is attached to extend across front frame 2a and rear frame 2b.
- Steering cylinder 11 is a hydraulic cylinder.
- the travel direction of wheel loader 1 is changed to the left or right by expansion/contraction of steering cylinder 11 caused by hydraulic oil from a steering pump.
- Front frame 2a and rear frame 2b constitute vehicular body frame 2 having an articulated structure.
- Wheel loader 1 is an articulated work machine having front frame 2a and rear frame 2b connected to each other in such a manner that they can be bent.
- Work implement 3 and a pair of running wheels (front wheels) 4a are attached to front frame 2a.
- Work implement 3 is attached to the front of the main body of wheel loader 1.
- Work implement 3 is supported by the vehicular body of wheel loader 1.
- Work implement 3 includes a boom 14 and a bucket 6.
- Bucket 6 is disposed at the distal end of work implement 3.
- Bucket 6 is a working tool for excavation and loading.
- a cutting edge 6a is the distal end of bucket 6.
- a back surface 6b is a part of the outer surface of bucket 6.
- Back surface 6b is formed as a flat surface. Back surface 6b extends rearward from cutting edge 6a.
- boom pin 9 The proximal end of boom 14 is rotatably attached to front frame 2a by a boom pin 9.
- Bucket 6 is rotatably attached to boom 14 by a bucket pin 17 located at the distal end of boom 14.
- Boom pin 9 and bucket pin 17 correspond to "a plurality of joints" of work implement 3.
- Work implement 3 further includes a bell crank 18 and a link 15.
- Bell crank 18 is rotatably supported on boom 14 by a support pin 18a located substantially at the center of boom 14.
- Link 15 is coupled to a coupling pin 18c provided at the distal end of bell crank 18.
- Link 15 connects bell crank 18 and bucket 6 to each other.
- Front frame 2a and boom 14 are connected by a pair of boom cylinders 16.
- Boom cylinder 16 is a hydraulic cylinder.
- Boom cylinder 16 rotationally drives boom 14 up and down about boom pin 9.
- the proximal end of boom cylinder 16 is attached to front frame 2a.
- the distal end of boom cylinder 16 is attached to boom 14.
- Boom cylinder 16 is a hydraulic actuator that moves boom 14 up and down with respect to front frame 2a. As boom 14 moves up and down, bucket 6 attached to the distal end of boom 14 also moves up and down.
- a bucket cylinder 19 connects bell crank 18 and front frame 2a to each other.
- the proximal end of bucket cylinder 19 is attached to front frame 2a.
- the distal end of bucket cylinder 19 is attached to a coupling pin 18b provided at the proximal end of bell crank 18.
- Bucket cylinder 19 is a hydraulic actuator that pivots bucket 6 up and down with respect to boom 14.
- Bucket cylinder 19 is a working tool cylinder that drives bucket 6.
- Bucket cylinder 19 rotationally drives bucket 6 about bucket pin 17.
- Bucket 6 is configured to be operable with respect to boom 14.
- Bucket 6 is configured to be operable with respect to front frame 2a.
- Boom cylinder 16 and bucket cylinder 19 correspond to one example of "work implement actuator” that drives work implement 3.
- Cab 5 on which an operator rides and a pair of running wheels (rear wheels) 4b are attached to rear frame 2b.
- Cab 5 in a box shape is located rearward with respect to boom 14.
- Cab 5 is placed on vehicular body frame 2.
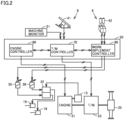
- Fig. 2 is a block diagram showing a schematic configuration of a control system that controls wheel loader 1.
- an engine 21 is a driving source that generates a driving force for driving work implement 3 and travel device 4 ( Fig. 1 ), and is, for example, a diesel engine.
- a motor driven by a power storage unit may be used as a driving source, instead of engine 21, or both the engine and the motor may be used as a driving source.
- the output of engine 21 is controlled by adjusting the amount of fuel injected into a cylinder of engine 21.
- the driving force generated by engine 21 is transmitted to a transmission 23.
- Transmission 23 changes the driving force to an appropriate torque and an appropriate rotational speed.
- An axle 25 is connected to an output shaft of transmission 23.
- the driving force changed by transmission 23 is transmitted to axle 25.
- the driving force is transmitted from axle 25 to running wheels 4a and 4b ( Fig. 1 ). Accordingly, wheel loader 1 travels.
- both of running wheels 4a and running wheels 4b constitute driving wheels that drive wheel loader 1 by the received driving force.
- Work implement pump 13 is a hydraulic pump that is driven by engine 21 to cause work implement 3 ( Fig. 1 ) to operate by its discharged hydraulic oil.
- Work implement 3 is driven by the hydraulic oil from work implement pump 13.
- the hydraulic oil discharged from work implement pump 13 is supplied to boom cylinder 16 and bucket cylinder 19 through a main valve 32.
- boom cylinder 16 expands and contracts by receiving the supplied hydraulic oil
- boom 14 moves up and down.
- bucket cylinder 19 expands and contracts by receiving the supplied hydraulic oil, bucket 6 pivots up and down.
- Wheel loader 1 includes a vehicular body controller 50.
- Vehicular body controller 50 includes an engine controller 60, a transmission controller 70, and a work implement controller 80.
- Vehicular body controller 50 is generally implemented by a CPU (Central Processing Unit) reading various programs. Vehicular body controller 50 includes a memory, which is not shown. The memory functions as a work memory and stores various programs for implementing functions of wheel loader 1.
- CPU Central Processing Unit
- Operation device 8 is provided on cab 5. Operation device 8 is operated by an operator. Operation device 8 includes a plurality of types of operation members that the operator operates in order to cause wheel loader 1 to operate. Operation device 8 includes an accelerator pedal 41 and a work implement operation lever 42. Operation device 8 may include a steering handle, a shift lever, and the like, which are not shown.
- Accelerator pedal 41 is operated to set a target rotational speed of engine 21.
- Engine controller 60 controls the output of engine 21 based on the operation amount of accelerator pedal 41.
- the operation amount of accelerator pedal 41 (the extent to which the pedal is depressed) is increased, the output of engine 21 is increased.
- the operation amount of accelerator pedal 41 is decreased, the output of engine 21 is decreased.
- Transmission controller 70 controls transmission 23 based on the operation amount of accelerator pedal 41.
- Work implement operation lever 42 is operated to cause work implement 3 to operate.
- Work implement controller 80 controls electromagnetic proportional control valves 35 and 36 based on the operation amount of work implement operation lever 42.
- Electromagnetic proportional control valve 35 switches main valve 32 so as to contract bucket cylinder 19 and thereby move bucket 6 in a dumping direction (a direction in which the cutting edge of bucket 6 is lowered). Electromagnetic proportional control valve 35 also switches main valve 32 so as to extend bucket cylinder 19 and thereby move bucket 6 in a tilt direction (a direction in which the cutting edge of bucket 6 is lifted). Electromagnetic proportional control valve 36 switches main valve 32 so as to contract boom cylinder 16 and thereby lower boom 14. Electromagnetic proportional control valve 36 also switches main valve 32 so as to extend boom cylinder 16 and thereby lift boom 14.
- a machine monitor 51 receives input of a command signal from vehicular body controller 50 to display various kinds of information.
- Various kinds of information displayed on machine monitor 51 may for example be information about a work performed by wheel loader 1, vehicular body information such as a remaining amount of fuel, a cooling water temperature, and a hydraulic oil temperature, a peripheral image obtained by imaging the periphery of wheel loader 1, and the like.
- Machine monitor 51 may be a touch panel and, in this case, a signal generated as a result of operator's touch of a part of machine monitor 51 is output from machine monitor 51 to vehicular body controller 50.
- Wheel loader 1 of the present embodiment performs an excavation-and-loading work of scooping out an excavation target, i.e., an object to be excavated, such as soil, rocks, and sand, and loading the excavation target on a loading target such as dump truck.
- Fig. 3 is a plan view of wheel loader 1 performing an excavation-and-loading work.
- Fig. 3 shows wheel loader 1 performing a so-called V-shape work.
- Fig. 3 (A) illustrates wheel loader 1 making a so-called empty-load advance.
- Wheel loader 1 travels forward along an excavation route R1 toward an excavation target 310 such as soil, rocks, and sand.
- Wheel loader 1 pushes bucket 6 into excavation target 310 and stops traveling forward.
- An excavation work of scooping out at least a part of excavation target 310 with bucket 6 is performed, by lifting bucket 6 with cutting edge 6a ( Fig. 1 ) of bucket 6 being caught in excavation target 310.
- Fig. 3 (B) illustrates wheel loader 1 making a so-called loaded retreat.
- Excavation target 310 is loaded as a load in bucket 6.
- Wheel loader 1 travels backward along excavation route R1 to the position where it started traveling forward in Fig. 3 (A) .
- Fig. 3 (C) illustrates wheel loader 1 making a so-called loaded advance.
- load excavation target 310
- wheel loader 1 travels forward toward a vessel 301 of a dump truck 300.
- Wheel loader 1 travels forward along a loading route R2 from the position where it started traveling forward in Fig. 3 (A) toward dump truck 300.
- wheel loader 1 loads the load 310 in bucket 6 into vessel 301.
- Vessel 301 corresponds to one example of "load container" into which load 310 in bucket 6 is loaded.
- Fig. 3 (D) illustrates wheel loader 1 making a so-called empty-load retreat.
- wheel loader 1 travels backward along loading route R2 to the position where it started traveling forward in Fig. 3 (C) .
- wheel loader 1 can repeatedly perform a series of operations: excavation, retreat, approaching the dump, discharging load, and retreat.
- Fig. 4 is a block diagram showing a configuration of an automatic control system of wheel loader 1.
- An automation controller 100 is configured to be capable of transmitting and receiving signals to and from vehicular body controller 50 described with reference to Fig. 2 .
- Automation controller 100 is also configured to be capable of transmitting and receiving signals to and from an external information acquisition unit 110.
- External information acquisition unit 110 includes a sensing device 111 and a position information acquisition device 112. Sensing device 111 and position information acquisition device 112 are mounted on wheel loader 1.
- Sensing device 111 acquires information about the surroundings of wheel loader 1. As shown in Fig. 1 , sensing device 111 is attached, for example, to an upper front surface of cab 5. Sensing device 111 corresponds to one example of "object sensor" that detects an object around the main body of wheel loader 1.
- Sensing device 111 detects the direction of an object outside wheel loader 1 and the distance to the object in a non-contact manner.
- Sensing device 111 is, for example, LiDAR (Light Detection and Ranging) that emits laser light to obtain information about an object.
- Sensing device 111 may be a visual sensor including a camera.
- Sensing device 111 may be Radar (Radio Detection and Ranging) that acquires information about an object by emitting radio waves.
- Sensing device 111 may also be an infrared sensor.
- Position information acquisition device 112 acquires information about the current position of wheel loader 1.
- Position information acquisition device 112 acquires information about the position of wheel loader 1 in a global coordinate system with respect to the earth, for example, by using a satellite positioning system.
- Position information acquisition device 112 uses, for example, GNSS (Global Navigation Satellite Systems), and has a GNSS receiver.
- the satellite positioning system calculates the position of wheel loader 1 by calculating the position of an antenna of the GNSS receiver based on positioning signals that the GNAA receiver has received from satellites.
- External information about wheel loader 1 acquired by sensing device 111 and position information about wheel loader 1 acquired by position information acquisition device 112 are input to automation controller 100.
- Vehicular body controller 50 is configured to be capable of transmitting and receiving signals to and from vehicle information acquisition unit 120, and receives input of information about wheel loader 1 acquired by vehicle information acquisition unit 120.
- Vehicle information acquisition unit 120 is constituted of various sensors mounted on wheel loader 1.
- Vehicle information acquisition unit 120 includes an articulation angle sensor 121, a vehicle speed sensor 122, a boom angle sensor 123, a bucket angle sensor 124, and a boom cylinder pressure sensor 125.
- Articulation angle sensor 121 detects an articulation angle which is an angle formed between front frame 2a and rear frame 2b, and generates a signal indicative of the detected articulation angle. Articulation angle sensor 121 outputs the signal indicative of the articulation angle to vehicular body controller 50.
- Vehicle speed sensor 122 detects the speed of moving wheel loader 1 by travel device 4 ( Fig. 1 ) by detecting the rotational speed of the output shaft of transmission 23 ( Fig. 2 ), for example, and generates a signal indicative of the detected vehicle speed. Vehicle speed sensor 122 outputs a signal indicative of the vehicle speed to vehicular body controller 50. Vehicle speed sensor 122 corresponds to one example of "travel sensor" that detects a traveling state of travel device 4 (travel unit).
- Bucket angle sensor 124 is constituted, for example, of a rotary encoder provided on a support pin 18a which is a rotation shaft of bell crank 18. Bucket angle sensor 124 detects the angle of bucket 6 with respect to boom 14, and generates a signal indicative of the detected angle of bucket 6. Bucket angle sensor 124 outputs the signal indicative of the angle of bucket 6 to vehicular body controller 50.
- Boom angle sensor 123 and bucket angle sensor 124 correspond to one example of "work implement attitude sensor” that detects the attitude of work implement 3.
- the work implement attitude sensor may be an angle sensor that detects the angle of bell crank 18 and an angle sensor that detects the angle of link 15, instead of or in addition to boom angle sensor 123 and bucket angle sensor 124.
- the work implement attitude sensor is not limited to the rotary encoder, and may be a stroke sensor, an IMU (Inertial Measurement Unit), a potentiometer, a visual sensor, or the like.
- the stroke sensor When the stroke sensor is used as the work implement attitude sensor, for example, the stroke sensor is attached to each of boom cylinder 16 and bucket cylinder 19. The stroke amount of each of cylinders 16 and 19 can be detected by the stroke sensor. Respective attitudes of boom 14 and bucket 6 can be detected from the stroke amounts.
- the IMU When the IMU is used as the work implement attitude sensor, for example, the IMU is attached to each of boom 14 and bucket 6. Each IMU detects angles (or angular velocities) and accelerations of the three axes. The attitudes of boom 14 and bucket 6 can be detected from the angles (or angular velocities) and accelerations of the three axes detected by the IMU.
- the potentiometer When the potentiometer is used as the work implement attitude sensor, for example, the potentiometer is attached to each of a vicinity of the boom 14 side end of boom cylinder 16 and a vicinity of the bell crank 18 side end of bucket cylinder 19. Respective potentiometers can detect the rotation angle of boom 14 with respect to the main body of wheel loader 1 and the rotation angle of bucket 6 with respect to boom 14. The attitude of work implement 3 can be detected from these rotation angles.
- Respective attitudes of boom 14 and bucket 6 can be detected from information about the images captured by the visual sensor.
- the visual sensor is, for example, an imaging device such as camera.
- Boom cylinder pressure sensor 125 detects the pressure on the bottom side of boom cylinder 16 (boom bottom pressure) and generates a signal indicative of the detected boom bottom pressure.
- the boom bottom pressure increases when bucket 6 is loaded with a load and decreases when the bucket is emptied.
- Boom cylinder pressure sensor 125 outputs the signal indicative of the boom bottom pressure to vehicular body controller 50.
- Vehicular body controller 50 outputs the information input from vehicle information acquisition unit 120 to automation controller 100.
- Automation controller 100 receives detected values of vehicle speed sensor 122, boom angle sensor 123, and bucket angle sensor 124 that are input through vehicular body controller 50.
- An actuator 140 is configured to be capable of transmitting and receiving signals to and from vehicular body controller 50. Actuator 140 is driven in response to a command signal from vehicular body controller 50. Actuator 140 includes a brake EPC (electromagnetic proportional control valve) 141 for actuating a brake of travel device 4, a steering EPC 142 for adjusting the travel direction of wheel loader 1, a work implement EPC 143 for causing work implement 3 to operate, and an HMT (Hydraulic Mechanical Transmission) 144.
- EPC electromechanical proportional control valve
- Electromagnetic proportional control valves 35 and 36 shown in Fig. 2 constitute work implement EPC 143.
- Transmission 23 shown in Fig. 2 is implemented as HMT 144 utilizing electronic control.
- Transmission 23 may be an HST (Hydro-Static Transmission).
- a power transmission device that transmits power from engine 21 to running wheels 4a and 4b may include an electric drive device of a diesel-electric transmission system or the like, or may include any combination of an HMT, an HST, and an electric drive device.
- Vehicular body controller 50 includes transmission controller 70 and work implement controller 80.
- Transmission controller 70 includes a brake control unit 71 and an accelerator control unit 72.
- Brake control unit 71 outputs a command signal for controlling actuation of the brake, to brake EPC 141.
- Accelerator control unit 72 outputs a command signal for controlling the vehicle speed, to HMT 144.
- Work implement controller 80 includes a steering control unit 81 and a work implement control unit 82.
- Steering control unit 81 outputs a command signal for controlling the travel direction of wheel loader 1, to steering EPC 142.
- Work implement control unit 82 outputs a command signal for controlling operation of work implement 3, to work implement EPC 143.
- Automation controller 100 includes a position estimation unit 101, a path planning unit 102, a route tracking control unit 103, and a load push determination unit 104.
- Position estimation unit 101 estimates the current position of wheel loader 1 based on the position information acquired by position information acquisition device 112. Position estimation unit 101 also recognizes a target position based on external information acquired by sensing device 111.
- the target position is, for example, the position of excavation target 310 or the position of dump truck 300 shown in Fig. 3 .
- Sensing device 111 may recognize the target position and input the target position to automation controller 100, or position estimation unit 101 may recognize the target position based on a detection result detected by sensing device 111.
- Path planning unit 102 generates an optimal route connecting the current position and the target position of wheel loader 1.
- the optimum route includes a route of traveling by travel device 4 and a route of operation of work implement 3.
- Route tracking control unit 103 controls the accelerator, the brake, and the steering so that wheel loader 1 tracks the optimum route generated by path planning unit 102.
- a command signal for causing wheel loader 1 to travel along the optimal route is output from route tracking control unit 103 to brake control unit 71, accelerator control unit 72, and steering control unit 81.
- Route tracking control unit 103 controls boom cylinder 16 and bucket cylinder 19 so that work implement 3 operates along the optimum route generated by path planning unit 102.
- a command signal for moving work implement 3 along the optimal route is output from route tracking control unit 103 to work implement control unit 82.
- An interface 130 is configured to be capable of transmitting and receiving signals to and from vehicular body controller 50.
- Interface 130 includes an automation switch 131, an engine emergency stop switch 132, and a mode lamp 133.
- Automation switch 131 is operated by an operator.
- the operator operates automation switch 131 to make a switch between manual operation of wheel loader 1 and automatic control of wheel loader 1.
- Engine emergency stop switch 132 is operated by an operator. When an event occurs that requires emergency stop of engine 21, the operator operates engine emergency stop switch 132. Signals for operations of automation switch 131 and engine emergency stop switch 132 are input to vehicular body controller 50.
- Mode lamp 133 indicates whether wheel loader 1 is currently in a mode of being manually operated by an operator or in an automatically controlled mode.
- a command signal for controlling lighting of the lamp is output from vehicular body controller 50 to mode lamp 133.
- the automatic control system of wheel loader 1 acquires information about a loading status (for example, load condition) of a load in vessel 301 for automating a load push in a loading work.
- the automatic control system of wheel loader 1 also detects information about the loading status of the load in vessel 301.
- the automatic control system of wheel loader 1 moves (pushes) the load in vessel 301 by causing wheel loader 1 to operate based on the detected information.
- the automatic control system of wheel loader 1 includes a "loading sensor" that detects information about the loading status of the load in vessel 301.
- the "loading sensor” detects information about a loading status of load 310 in vessel 301.
- the loading sensor may include, for example, at least one of the “object sensor” and the “work implement attitude sensor” described above. That is, the loading sensor may be the “object sensor” alone, or the “work implement attitude sensor” alone, or may include both the “object sensor” and the “work implement attitude sensor.”
- a signal indicating the loading status of load 310 in vessel 301 detected by the object sensor serves as information about the loading status of load 310 in vessel 301.
- the loading status of load 310 in vessel 301 is detected by sensing device 111, which is one example of the object sensor.
- the loading status of load 310 in vessel 301 is detected by any one or any combination of a LiDAR, a visual sensor, a Radar, an infrared sensor, and the like, which are each an example of sensing device 111.
- a signal indicating the attitude of work implement 3 detected by the work implement attitude sensor serves as information about the loading status of load 310 in vessel 301.
- a signal indicating the attitude of work implement 3 is detected by any one or any combination of a rotary encoder, a stroke sensor, an IMU, a potentiometer, a visual sensor, and the like, which are each an example of the work implement attitude sensor.
- the automatic control system of wheel loader 1 includes load push determination unit 104 that determines whether or not it is necessary to push load 310 in vessel 301, based on the information about the loading status of load 310 in vessel 301.
- Load push determination unit 104 is included in automation controller 100.
- Load push determination unit 104 determines whether or not it is necessary to push load 310 in vessel 301, based on the information detected by the loading sensor. When the information about the loading status is detected by the object sensor alone, load push determination unit 104 determines whether or not it is necessary to push load 310 in vessel 301, based on the information about the loading status of load 310 in vessel 301 acquired by sensing device 111, for example.
- automation controller 100 has stored, for example, relationship data indicating a relationship between the loading status of load 310 in vessel 301 and whether it is necessary to push the load.
- Load push determination unit 104 determines whether or not it is necessary to move load 310 in vessel 301, by comparing the relationship data with the information about the loading status of load 310 in vessel 301 acquired by sensing device 111.
- load push determination unit 104 calculates the number of times load 310 has been loaded into vessel 301 by work implement 3, from a signal indicating the attitude of work implement 3 acquired by the work implement attitude sensor, for example.
- load push determination unit 104 determines that it is necessary to pushy load 310 in vessel 301.
- the signal indicating the number of times of loading corresponds to the information about the loading status of load 310 in vessel 301.
- the information about the loading status may be detected by both the object sensor and the work implement attitude sensor. In this case, it is determined whether or not it is necessary to push load 310 in vessel 301, based on both the information about the loading status detected by the object sensor and the information about the loading status detected by the work implement attitude sensor.
- automation controller 100 causes wheel loader 1 to operate so as to push load 310 toward center CL of vessel 301.
- path planning unit 102 when load push determination unit 104 determines that it is necessary to push load 310 in vessel 301, path planning unit 102 generates a route for causing wheel loader 1 to operate so as to move load 310 toward center CL of vessel 301. Then, route tracking control unit 103 controls the accelerator, the brake, the steering, boom cylinder 16, and bucket cylinder 19, so that wheel loader 1 tracks the route generated by path planning unit 102 and work implement 3 operates.
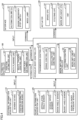
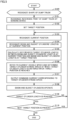
- Fig. 5 is a flowchart showing a flow of an operation of loading, onto a loading target, a load loaded on bucket 6, by automatically controlling wheel loader 1.
- step S100 the shape of vessel 301 of dump truck 300, which is a loading target on which a load is to be loaded, is recognized in advance before a loading work is started.
- the shape of dump truck 300 is acquired by a LiDAR, which is sensing device 111.
- Laser light is applied from the LiDAR to dump truck 300 to acquire point group data indicating three-dimensional coordinate values of measurement points on dump truck 300.
- Dump truck 300 is sensed from the front, rear, right, and left sides, so that the shape of vessel 301 can be recognized from the point group information.
- the recognized shape of vessel 301 is input to automation controller 100.
- sensing device 111 recognizes a reference point P ( Fig. 7 ) of dump truck 300.
- the LiDAR which is sensing device 111
- Automation controller 100 recognizes the position of vessel 301 by comparing the point group detected by sensing device 111 with a master point group indicating the shape of vessel 301.
- Automation controller 100 sets reference point P at an upper end of a side surface of vessel 301 of dump truck 300 recognized by the LiDAR, which is sensing device 111.
- step S102 automation controller 100 sets coordinates of target positions c, d, and e ( Fig. 7 ) of cutting edge 6a of bucket 6 moved by automatic control, with respect to reference point P.
- Cutting edge 6a of bucket 6 corresponds to one example of "feature point" set on work implement 3.
- the feature point is not limited to cutting edge 6a of bucket 6, and any of other points on work implement 3 may be set as the feature point.
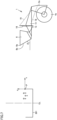
- FIG. 7 is a diagram schematically showing an arrangement of vessel 301 and wheel loader 1 at the start of approaching a dump.
- vessel 301 as seen in the front-rear direction of dump truck 300 is schematically shown, and a part of a front portion of wheel loader 1 approaching vessel 301 from the left side or the right side of dump truck 300 is schematically shown.
- Target position c is set as a position through which cutting edge 6a of bucket 6 passes while wheel loader 1 is traveling forward toward dump truck 300. During the forward travel of wheel loader 1, an operation of work implement 3 for moving bucket 6 in the dumping direction is performed in order to load the load 310 in bucket 6 into vessel 301. The position at the time cutting edge 6a of bucket 6 performing dumping during a loading operation is located at the lowermost position is target position c.
- Target position d is set as a position through which cutting edge 6a of bucket 6 passes after passing through target position c.
- Target position d is set closer to reference point P than target position c.
- Target position d is a position at which the operation of bucket 6 in the dumping direction is stopped.
- target position d is a position at which load push is started.
- Target position d is a position at which the operation of work implement 3 is stopped while bucket 6 is maintained in the full dump state, for example.
- Target position e is set as a position through which cutting edge 6a of bucket 6 passes after passing through target position d.
- Target position e is set farther from reference point P than target position d. From target position d to target position e, the state in which the operation of work implement 3 is stopped is maintained in the state in which bucket 6 is in the full dump state, for example, and the forward travel of wheel loader 1 is continued.
- Target position e is located above vessel 301.
- an xy coordinate system having reference point P as the origin is defined.
- the x-axis is the left-right direction of dump truck 300 through reference point P.
- the direction away from vessel 301 with respect to reference point P is +x direction.
- the y-axis is the top-bottom direction through reference point P.
- the upward direction from reference point P is +y direction.
- a bucket angle ⁇ shown in Fig. 7 is an angle formed by the ground and back surface 6b of bucket 6.
- Bucket angle ⁇ may also be an angle formed by back surface 6b of bucket 6 and a horizontal plane with respect to the vehicular body.
- Target positions c, d, and e are determined by giving respective positions of cutting edge 6a of bucket 6 in the horizontal direction and the vertical direction with respect to reference point P, that is, the x-coordinate and the y-coordinate.
- Target position c is set as a position at which the height position of cutting edge 6a is the lowest (the y-coordinate has the minimum value) while discharging load 310 from bucket 6.
- Target position c is set to a position where the y-coordinate is on the negative side.
- the y-coordinates of target positions d and e are set to positions on the positive side.
- Target positions c, d, and e are set at respective positions having respective x-coordinates on the negative side.
- Target positions d and e are set at the same y-coordinate, for example.
- bucket 6 may not be in the full dump state, but may be in a dump state in which load 310 in bucket 6 can be loaded into vessel 301.
- target positions d and e may not be at the same y-coordinate, and target position e may be a position (position in the -y direction) lower than target position d.
- Bucket angle ⁇ at the time cutting edge 6a of bucket 6 is located at each target position is also set.
- the attitude of work implement 3 at the time cutting edge 6a of bucket 6 is located at each target position is determined from the x-coordinate and the y-coordinate of each target position and bucket angle ⁇ at each target position.
- Automation controller 100 stores the attitude (target attitude) of work implement 3 at the time cutting edge 6a of bucket 6 is located at each target position.
- the length of boom cylinder 16 and the length of bucket cylinder 19 at the time cutting edge 6a of bucket 6 is located at each target position are determined, based on the target attitude at the time cutting edge 6a of bucket 6 is located at the target position.
- the x-coordinate and the y-coordinate of each target position and bucket angle ⁇ at each target position can be determined by analyzing the trajectory of cutting edge 6a while a skilled operator performs a loading work, extracting a characteristic position, and extracting the attitude of work implement 3 at the characteristic position.
- Fig. 8 is a diagram schematically showing an attitude of the wheel loader at the time the cutting edge of the bucket is located at the lowermost position during a loading operation.
- Fig. 9 is a diagram schematically showing an attitude of the wheel loader at the start of load push.
- Fig. 10 is a diagram schematically showing an attitude of the wheel loader at the time load push is ended.
- cutting edge 6a of bucket 6 is located at target position c.
- cutting edge 6a is located at target position d.
- Fig. 10 cutting edge 6a is located at target position e.
- Fig. 11 is a graph showing change of the cylinder length during a loading work.
- the horizontal axis of Fig. 11 represents elapse of time, and auxiliary lines are drawn at respective times at which cutting edge 6a passes through target positions c, d, and e.
- the vertical axis in Fig. 11 represents the length of boom cylinder 16 and bucket cylinder 19.
- wheel loader 1 is traveling forward before cutting edge 6a reaches target position c.
- the length of boom cylinder 16 is increasing and accordingly boom 14 is rising.
- the length of bucket cylinder 19 continues decreasing, so that bucket 6 continues moving in the dumping direction.
- cutting edge 6a is located at the lowermost position during the loading operation.
- wheel loader 1 may continue the backward travel, the length of boom cylinder 16 may be decreased (boom 14 may be lowered), and the length of bucket cylinder 19 may be increased (bucket 6 may be moved in the tilt direction).
- cutting edge 6a of bucket 6 can be moved to pass through target positions c and d in this order, to discharge load 310 from within bucket 6 into vessel 301. Moreover, cutting edge 6a of bucket 6 can be moved to pass through target positions d and e in this order, to push load 310 in vessel 301 by bucket 6. For example, load 310 in vessel 301 can be pushed toward center CL of vessel 301 by bucket 6.
- automatic control for moving bucket 6 can be applied to wheel loader 1 to perform the operation of wheel loader 1, including the load discharging operation and the load push operation that are equivalent to operations performed under operation of a skilled operator.
- step S103 automation controller 100 recognizes respective current positions of wheel loader 1 and work implement 3.
- position information acquisition device 112 By acquiring the current position of the vehicular body of wheel loader 1 by means of position information acquisition device 112 and acquiring the attitude of the work implement with respect to the vehicular body by means of boom angle sensor 123 and the bucket angle sensor 124, respective current positions of wheel loader 1 and work implement 3 in the global coordinate system can be recognized.
- the relative position of cutting edge 6a of bucket 6 with respect to vessel 301 of dump truck 300 can be calculated based on the current positions of wheel loader 1 and work implement 3 and the current position of dump truck 300 in the global coordinate system.
- sensing device 111 may be used to acquire the direction and the distance of reference point P of vessel 301 of dump truck 300 with respect to the position where sensing device 111 is arranged, to calculate the current relative position of cutting edge 6a of bucket 6 with respect to reference point P.
- the position of cutting edge 6a of bucket 6 with respect to each of target positions c to e is recognized from the current position of work implement 3. For example, it is recognized that cutting edge 6a has not yet reached target position c, or that cutting edge 6a has passed through target position c and is located between target position c and target position d, or that cutting edge 6a has passed through target position d and is located between target position d and target position e. Further, a target position toward which cutting edge 6a is moved next is recognized.
- next target position is target position c
- cutting edge 6a is located between target position c and target position d
- next target position is target position d
- cutting edge 6a is located between target position d and target position e
- the next target position is target position e.
- step S104 automation controller 100 recognizes the length of boom cylinder 16 and the length of bucket cylinder 19 at the current position.
- Boom angle sensor 123 detects the angle of boom 14.
- Bucket angle sensor 124 detects the angle of bucket 6.
- the attitude of work implement 3 is determined from the angle of boom 14 and the angle of bucket 6.
- the length of boom cylinder 16 and the length of bucket cylinder 19 at the current position are recognized based on the attitude of work implement 3.
- an angle sensor for detecting the angle of the bell crank 18 and an angle sensor for detecting the angle of link 15 may be provided.
- a stroke sensor, an IMU, a potentiometer, a visual sensor, or the like may detect the attitude of work implement 3.
- step S105 automation controller 100 calculates the differences between the length of boom cylinder 16 and the length of bucket cylinder 19 at the current position recognized in step S104, and the length of boom cylinder 16 and the length of bucket cylinder 19 at the target position toward which cutting edge 6a is moved next (referred to as the target cylinder length hereinafter). Automation controller 100 calculates the distance to move cylinders 16, 19 required for cutting edge 6a to reach the next target position.
- automation controller 100 refers to the current vehicle speed and determines a target cylinder stroke speed at which the target cylinder length is obtained when cutting edge 6a reaches the next target position.
- automation controller 100 controls boom cylinder 16 and bucket cylinder 19 so that work implement 3 takes the target attitude corresponding to the target position.
- the current vehicle speed is acquired by vehicle speed sensor 122. From the current position of cutting edge 6a and the current vehicle speed, the time required to reach the next target position is calculated.
- the target cylinder stroke speed is determined by dividing the difference in cylinder length calculated in step S105 by the time taken to reach the next target position.
- the cylinder stroke amount while wheel loader 1 travels a unit distance may be determined.
- the fact that wheel loader 1 has traveled a unit distance may be obtained from the vehicle speed or may be detected by sensing device 111.
- step S107 automation controller 100 outputs, to vehicular body controller 50, a command current corresponding to the target cylinder stroke speed.
- Automation controller 100 outputs, to work implement control unit 82 of work implement controller 80, a command to expand and contract boom cylinder 16 and bucket cylinder 19 at the target cylinder stroke speed.
- the command to expand and contract boom cylinder 16 and bucket cylinder 19 at the target cylinder stroke speed is output from work implement control unit 82 to work implement EPC 143.
- step S108 work implement EPC 143 that has received the command signal adjusts the opening degree to cause appropriate hydraulic oil to be supplied to boom cylinder 16 and bucket cylinder 19.
- boom cylinder 16 and bucket cylinder 19 operate.
- step S109 automation controller 100 recognizes respective current lengths of boom cylinder 16 and bucket cylinder 19, similarly to step S104. Automation controller 100 determines whether the respective current lengths of boom cylinder 16 and bucket cylinder 19 have reached the target cylinder length.
- step S109 When it is determined in step S109 that the target cylinder length has been reached (YES in step S109), the flow proceeds to step S110, and automation controller 100 determines whether or not there is a next target position.
- step S109 When it is determined in step S109 that the target cylinder length has not been reached (NO in step S109) and it is determined in step S110 that there is a next target position (YES in step S110), the flow returns to step S103 and the process of expanding and contracting boom cylinder 16 and bucket cylinder 19 is repeated based on the current position of work implement 3.
- the cylinder speed is sequentially changed depending on the current position of cutting edge 6a of bucket 6.
- the cylinder speed is adjusted.
- step S110 When it is determined in step S110 that there is no next target position (NO in step S110), the loading work is ended.
- this condition corresponds to the fact that the next target position is not set after target position d is reached.
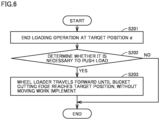
- Fig. 6 is a flowchart showing automatic control of load push.
- cutting edge 6a of bucket 6 reaches target position d as shown in Fig. 9 .
- Whether or not cutting edge 6a has reached target position d is determined by automation controller 100 based on whether or not respective lengths of boom cylinder 16 and bucket cylinder 19 have reached the target length for target position d in the automatic control flow of Fig. 5 .
- bucket 6 has become the full dump state. Therefore, the operation for loading the load 310 in bucket 6 into vessel 301 is ended (step S201, Fig. 6 ).
- Automation controller 100 has acquired information about the loading status of load 310 in vessel 301. When cutting edge 6a of bucket 6 reaches target position d, automation controller 100 determines whether to push load 310 in vessel 301 (step S202, Fig. 6 ). The acquisition of the information about the loading status and the determination as to whether or not it is necessary to push the load are performed by load push determination unit 104 of automation controller 100.
- Load push determination unit 104 determines whether it is necessary to push load 310 in vessel 301, based on the information about the loading status of load 310 in vessel 301. Load push determination unit 104 determines whether it is necessary to push load 310 in vessel 301, based on the information about the loading status of load 310 in vessel 301 acquired by sensing device 111, for example.
- automation controller 100 has stored relationship data indicating a relationship between the loading status of load 310 in vessel 301 and whether it is necessary to push the load.
- Load push determination unit 104 determines whether it is necessary to push load 310 in vessel 301, by comparing the relationship data with the information about the loading status of load 310 in vessel 301 acquired by sensing device 111.
- load push determination unit 104 calculates the number of times load 310 has been loaded into vessel 301 by work implement 3, from a signal indicating the attitude of work implement 3 acquired by a work implement attitude sensor, for example. When the calculated number of times of loading is equal to or more than a predetermined number of times (for example, two), load push determination unit 104 determines that it is necessary to push load 310 in vessel 301.
- a predetermined number of times for example, two
- step S202 when load push determination unit 104 determines that it is necessary to push load 310 in vessel 301, path planning unit 102 generates a route along which wheel loader 1 is to be operated, so that cutting edge 6a moves from target position d to target position e.
- Route tracking control unit 103 controls the accelerator, the brake, and the steering so that wheel loader 1 tracks the route generated by path planning unit 102.
- a command signal for causing wheel loader 1 to travel along an optimal route is output from route tracking control unit 103 to brake control unit 71, accelerator control unit 72, and steering control unit 81.
- wheel loader 1 is controlled to travel forward from target position d to target position e, by route tracking control unit 103.
- route tracking control unit 103 controls boom cylinder 16 and bucket cylinder 19 so that work implement 3 operates along the optimum route generated by path planning unit 102.
- a command signal to move work implement 3 along the optimal route is output from route tracking control unit 103 to work implement control unit 82.
- work implement 3 is controlled by route tracking control unit 103 to stop its operation from target position d to target position e.
- route tracking control unit 103 performs control to cause wheel loader 1 to travel forward and cause work implement 3 to stop its operation, until target position e is reached from target position d (step S203, Fig. 6 ). Accordingly, wheel loader 1 is operated to push load 310 in vessel 301 toward center CL of vessel 301. When cutting edge 6a reaches target position e, the load push control is ended.
- load push determination unit 104 determines in step S202 that it is not necessary to push load 310 in vessel 301, the load push control is ended.
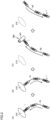
- a load 310A is loaded in vessel 301 by loading performed for the first time, and a load 310B is loaded in the vessel by loading performed for the second time. For example, at the time the second loading is completed, load 310 loaded in vessel 301 may be unbalanced.
- the load push is performed by moving cutting edge 6a of bucket 6 from the end of vessel 301 toward center CL. In this way, load 310 in vessel 301 is pushed by bucket 6 to move to center CL of vessel 301.
- wheel loader 1 After cutting edge 6a reaches target position e, wheel loader 1 travels backward. Thus, bucket 6 moves backward away from dump truck 300 while forming an apex of 310.
- center CL of vessel 301 refers to the center of vessel 301 in the width direction in a cross section of vessel 301 in the direction in which wheel loader 1 travels forward toward vessel 301 during the loading operation (in the cross section shown in Fig. 12 (A) to (C) ).
- automation controller 100 (load push determination unit 104) shown in Fig. 4 acquires information about the loading status of load 310 in vessel 301.
- Automation controller 100 (load push determination unit 104) also determines whether or not it is necessary to push load 310 in vessel 301, based on the information about the loading status of load 310 in vessel 301.
- automation controller 100 (load push determination unit 104) operates wheel loader 1 to move load 310 toward center CL of vessel 301.
- load 310 is pushed toward center CL of vessel 301, based on the loading status of load 310 in vessel 301. Therefore, unbalance of load 310 in vessel 301 is improved. This prevents load 310 from spilling from vessel 301 while dump truck 300 is traveling.
- automation controller 100 load push determination unit 104 shown in Fig. 4 determines it is necessary to move load 310 in vessel 301
- automation controller 100 operates wheel loader 1 to move load 310 toward center CL of vessel 301 by causing travel device 4 to travel forward. Accordingly, it is possible to cause bucket 6 to push load 310 in vessel 301 toward center CL of vessel 301.
- automation controller 100 load push determination unit 104 shown in Fig. 4 determines it is necessary to move load 310 in vessel 301
- automation controller 100 load push determination unit 104 causes travel device 4 to travel forward while stopping driving the work implement actuator, to thereby operate wheel loader 1 to move load 310 toward center CL of vessel 301. Accordingly, operation control of the work implement actuator while the load is pushed is unnecessary, which makes it possible to simplify operation control.
- automation controller 100 when automation controller 100 (load push determination unit 104) shown in Fig. 4 determines it is necessary to move load 310 in vessel 301, automation controller 100 (load push determination unit 104) operates wheel loader 1 to move load 310 toward center CL of vessel 301 by causing travel device 4 to travel forward while keeping the height of bucket 6. This eliminates the need to control the height of bucket 6 while the load is pushed, which makes it possible to simplify operation control.
- automation controller 100 load push determination unit 104 shown in Fig. 4 calculates the number of times loading into vessel 301 by work implement 3 is performed, based on the attitude of work implement 3 detected by the work implement attitude sensor, and determines whether or not it is necessary to move load 310 in vessel 301, based on the calculated number of times of loading. This makes it possible to easily determine whether or not it is necessary to push the load, based on the number of times of loading.
- automation controller 100 load push determination unit 104 shown in Fig. 4 determines whether or not it is necessary to move load 310 in vessel 301, based on the loading status of load 310 detected by the object sensor. Accordingly, it can be determined whether or not it is necessary to push the load, in accordance with the actual loading status of load 310 in vessel 301. It is therefore possible to more accurately prevent load 310 from spilling from vessel 301 while dump truck 300 is traveling.
- a work machine including:
- the work machine further including a work implement attitude sensor that detects an attitude of the work implement, for determining the loading status of the load, wherein the controller calculates the number of times the work implement has performed loading into the load container, based on the attitude of the work implement detected by the work implement attitude sensor, and determines whether it is necessary to move the load in the load container, based on the calculated number of times.
- the work machine according to any one of Appendix 1 to Appendix 5, further including an object sensor that detects the loading status of the load loaded into the load container, for determining the loading status of the load, wherein the controller determines whether it is necessary to move the load in the load container, based on the loading status of the load detected by the object sensor.
- a method for controlling a work machine including:
Landscapes
- Engineering & Computer Science (AREA)
- Mining & Mineral Resources (AREA)
- Civil Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Structural Engineering (AREA)
- Mechanical Engineering (AREA)
- Operation Control Of Excavators (AREA)
Abstract
Description
- The present disclosure relates to a work machine, a system including the work machine, and a method for controlling the work machine.
-
WO2016/152994 (PTL 1) discloses control to move a boom and a bucket to a target position that is determined depending on a distance for which a wheel loader has traveled. - PTL 1:
WO2016/152994 - When loading into a load container such as a vessel of a dump truck is performed by a work machine such as a wheel loader, the loading work is usually performed multiple times. When the amount of loads loaded onto the dump truck by the loading work performed multiple times reaches the load capacity of the dump truck, loads may spill out while the dump truck is traveling, if the loading state (load condition) of the loaded loads is inappropriate.
- The present disclosure proposes a work machine, a system including the work machine, and a method for controlling the work machine that enable appropriate loading into a load container.
- A work machine and a system including the work machine according to an aspect of the present disclosure each include: a main body, a work implement, a work implement actuator, and a controller. The work implement is attached to the main body and loads a load into a load container. The work implement actuator drives the work implement with respect to the main body. The controller commands the work implement actuator to drive, based on a detected value of a position of the work implement and a detected value of a position of the load container with respect to the work machine. The controller acquires information about a loading status of a load in the load container, determines whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load, and operates, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- A method for controlling a work machine according to an aspect of the present disclosure includes: acquiring information about a loading status of a load in a load container; determining whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load; and operating, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- The work machine, a system including the work machine, and a method for controlling the work machine according to the present disclosure enable appropriate loading into the load container.
-
-
Fig. 1 is a side view of a wheel loader as one example of a work machine. -
Fig. 2 is a block diagram showing a schematic configuration of a control system of the wheel loader. -
Fig. 3 is a plan view of the wheel loader performing an excavation-and-loading work. -
Fig. 4 is a block diagram showing a configuration of an automatic control system of the wheel loader. -
Fig. 5 is a flowchart showing a flow of an operation of loading, onto a loading target, a load loaded on a bucket under automatic control. -
Fig. 6 is a flowchart showing automatic control of load push. -
Fig. 7 is a diagram schematically showing an arrangement of a vessel and the wheel loader at the start of approaching a dump. -
Fig. 8 is a diagram schematically showing an attitude of the wheel loader at the time a cutting edge of a bucket is located at the lowermost position during a loading operation. -
Fig. 9 is a diagram schematically showing an attitude of the wheel loader at the start of load push. -
Fig. 10 is a diagram schematically showing an attitude of the wheel loader at the time load push is ended. -
Fig. 11 is a graph showing change of the cylinder length during a loading work. -
Fig. 12 is a diagram showing change of the load condition in a vessel caused by load push. - Embodiments are described hereinafter based on the drawings. In the following description, the same parts or elements are denoted by the same reference characters. They have the same names and functions. Therefore, a detailed description thereof is not herein repeated. It is originally intended that any features are extracted from embodiments and combined as appropriate.
- In connection with an embodiment, a
wheel loader 1 is described as one example of the work machine.Fig. 1 is a side view ofwheel loader 1 as one example of the work machine. - As shown in
Fig. 1 ,wheel loader 1 includes avehicular body frame 2, a work implement 3, atravel device 4, and acab 5. The vehicular body ofwheel loader 1 is made up ofvehicular body frame 2 andcab 5, for example. To the vehicular body ofwheel loader 1, work implement 3 andtravel device 4 are attached. The main body ofwheel loader 1 includes a vehicular body andtravel device 4. -
Travel device 4 causes the vehicular body ofwheel loader 1 to travel, and includes runningwheels Wheel loader 1 is a wheeled vehicle including runningwheels Wheel loader 1 is capable of being self-propelled by rotationally driving runningwheels Travel device 4 corresponds to one example of "travel unit. " - The direction in which
wheel loader 1 travels straight is herein referred to as front-rear direction ofwheel loader 1. In the front-rear direction ofwheel loader 1, the side wherework implement 3 is located, with respect tovehicular body frame 2, is defined as front direction, and the side opposite to the front direction is defined as rear direction. The left-right direction ofwheel loader 1 is a direction orthogonal to the front-rear direction as seen in a plan view ofwheel loader 1 on a flat ground. The right side and the left side in the left-right direction, with respect to the front direction, are right direction and left direction, respectively. The top-bottom direction ofwheel loader 1 is a direction orthogonal to a plane defined by the front-rear direction and the left-right direction. In the top-bottom direction, the side where the ground is located is the lower side, and the side where the sky is located is the upper side. -
Vehicular body frame 2 includes afront frame 2a and arear frame 2b.Front frame 2a is disposed frontward with respect torear frame 2b.Front frame 2a andrear frame 2b are attached to each other in such a manner that they can swing in the left-right direction. - A pair of
steering cylinders 11 is attached to extend acrossfront frame 2a andrear frame 2b.Steering cylinder 11 is a hydraulic cylinder. The travel direction ofwheel loader 1 is changed to the left or right by expansion/contraction ofsteering cylinder 11 caused by hydraulic oil from a steering pump.Front frame 2a andrear frame 2b constitutevehicular body frame 2 having an articulated structure.Wheel loader 1 is an articulated work machine havingfront frame 2a andrear frame 2b connected to each other in such a manner that they can be bent. - Work implement 3 and a pair of running wheels (front wheels) 4a are attached to
front frame 2a. Work implement 3 is attached to the front of the main body ofwheel loader 1. Work implement 3 is supported by the vehicular body ofwheel loader 1. Work implement 3 includes aboom 14 and abucket 6.Bucket 6 is disposed at the distal end of work implement 3.Bucket 6 is a working tool for excavation and loading. Acutting edge 6a is the distal end ofbucket 6. Aback surface 6b is a part of the outer surface ofbucket 6. Backsurface 6b is formed as a flat surface. Backsurface 6b extends rearward from cuttingedge 6a. - The proximal end of
boom 14 is rotatably attached tofront frame 2a by a boom pin 9.Bucket 6 is rotatably attached to boom 14 by abucket pin 17 located at the distal end ofboom 14. Boom pin 9 andbucket pin 17 correspond to "a plurality of joints" of work implement 3. - Work implement 3 further includes a bell crank 18 and a
link 15. Bell crank 18 is rotatably supported onboom 14 by asupport pin 18a located substantially at the center ofboom 14.Link 15 is coupled to acoupling pin 18c provided at the distal end ofbell crank 18.Link 15 connects bell crank 18 andbucket 6 to each other. -
Front frame 2a andboom 14 are connected by a pair ofboom cylinders 16.Boom cylinder 16 is a hydraulic cylinder.Boom cylinder 16 rotationally drives boom 14 up and down about boom pin 9. The proximal end ofboom cylinder 16 is attached tofront frame 2a. The distal end ofboom cylinder 16 is attached toboom 14.Boom cylinder 16 is a hydraulic actuator that movesboom 14 up and down with respect tofront frame 2a. Asboom 14 moves up and down,bucket 6 attached to the distal end ofboom 14 also moves up and down. - A
bucket cylinder 19 connects bell crank 18 andfront frame 2a to each other. The proximal end ofbucket cylinder 19 is attached tofront frame 2a. The distal end ofbucket cylinder 19 is attached to acoupling pin 18b provided at the proximal end ofbell crank 18.Bucket cylinder 19 is a hydraulic actuator that pivotsbucket 6 up and down with respect toboom 14.Bucket cylinder 19 is a working tool cylinder that drivesbucket 6.Bucket cylinder 19rotationally drives bucket 6 aboutbucket pin 17.Bucket 6 is configured to be operable with respect toboom 14.Bucket 6 is configured to be operable with respect tofront frame 2a. -
Boom cylinder 16 andbucket cylinder 19 correspond to one example of "work implement actuator" that drives work implement 3. -
Cab 5 on which an operator rides and a pair of running wheels (rear wheels) 4b are attached torear frame 2b.Cab 5 in a box shape is located rearward with respect toboom 14.Cab 5 is placed onvehicular body frame 2. A seat on which an operator ofwheel loader 1 sits and an operation device 8 (Fig. 2 ) described later herein, for example, are disposed incab 5. -
Fig. 2 is a block diagram showing a schematic configuration of a control system that controlswheel loader 1. - As shown in
Fig. 2 , anengine 21 is a driving source that generates a driving force for driving work implement 3 and travel device 4 (Fig. 1 ), and is, for example, a diesel engine. A motor driven by a power storage unit may be used as a driving source, instead ofengine 21, or both the engine and the motor may be used as a driving source. The output ofengine 21 is controlled by adjusting the amount of fuel injected into a cylinder ofengine 21. - The driving force generated by
engine 21 is transmitted to atransmission 23.Transmission 23 changes the driving force to an appropriate torque and an appropriate rotational speed. Anaxle 25 is connected to an output shaft oftransmission 23. The driving force changed bytransmission 23 is transmitted toaxle 25. The driving force is transmitted fromaxle 25 to runningwheels Fig. 1 ). Accordingly,wheel loader 1 travels. Inwheel loader 1 of the present embodiment, both of runningwheels 4a and runningwheels 4b constitute driving wheels that drivewheel loader 1 by the received driving force. - A part of the driving force of
engine 21 is transmitted to a work implementpump 13. Work implementpump 13 is a hydraulic pump that is driven byengine 21 to cause work implement 3 (Fig. 1 ) to operate by its discharged hydraulic oil. Work implement 3 is driven by the hydraulic oil from work implementpump 13. The hydraulic oil discharged from work implementpump 13 is supplied toboom cylinder 16 andbucket cylinder 19 through amain valve 32. Asboom cylinder 16 expands and contracts by receiving the supplied hydraulic oil,boom 14 moves up and down. Asbucket cylinder 19 expands and contracts by receiving the supplied hydraulic oil,bucket 6 pivots up and down. -
Wheel loader 1 includes avehicular body controller 50.Vehicular body controller 50 includes anengine controller 60, atransmission controller 70, and a work implementcontroller 80. -
Vehicular body controller 50 is generally implemented by a CPU (Central Processing Unit) reading various programs.Vehicular body controller 50 includes a memory, which is not shown. The memory functions as a work memory and stores various programs for implementing functions ofwheel loader 1. -
Operation device 8 is provided oncab 5.Operation device 8 is operated by an operator.Operation device 8 includes a plurality of types of operation members that the operator operates in order to causewheel loader 1 to operate.Operation device 8 includes anaccelerator pedal 41 and a work implementoperation lever 42.Operation device 8 may include a steering handle, a shift lever, and the like, which are not shown. -
Accelerator pedal 41 is operated to set a target rotational speed ofengine 21.Engine controller 60 controls the output ofengine 21 based on the operation amount ofaccelerator pedal 41. When the operation amount of accelerator pedal 41 (the extent to which the pedal is depressed) is increased, the output ofengine 21 is increased. When the operation amount ofaccelerator pedal 41 is decreased, the output ofengine 21 is decreased.Transmission controller 70controls transmission 23 based on the operation amount ofaccelerator pedal 41. - Work implement
operation lever 42 is operated to cause work implement 3 to operate. Work implementcontroller 80 controls electromagneticproportional control valves operation lever 42. - Electromagnetic
proportional control valve 35 switchesmain valve 32 so as to contractbucket cylinder 19 and thereby movebucket 6 in a dumping direction (a direction in which the cutting edge ofbucket 6 is lowered). Electromagneticproportional control valve 35 also switchesmain valve 32 so as to extendbucket cylinder 19 and thereby movebucket 6 in a tilt direction (a direction in which the cutting edge ofbucket 6 is lifted). Electromagneticproportional control valve 36 switchesmain valve 32 so as to contractboom cylinder 16 and therebylower boom 14. Electromagneticproportional control valve 36 also switchesmain valve 32 so as to extendboom cylinder 16 and thereby liftboom 14. - A
machine monitor 51 receives input of a command signal fromvehicular body controller 50 to display various kinds of information. Various kinds of information displayed onmachine monitor 51 may for example be information about a work performed bywheel loader 1, vehicular body information such as a remaining amount of fuel, a cooling water temperature, and a hydraulic oil temperature, a peripheral image obtained by imaging the periphery ofwheel loader 1, and the like. Machine monitor 51 may be a touch panel and, in this case, a signal generated as a result of operator's touch of a part of machine monitor 51 is output from machine monitor 51 tovehicular body controller 50. -
Wheel loader 1 of the present embodiment performs an excavation-and-loading work of scooping out an excavation target, i.e., an object to be excavated, such as soil, rocks, and sand, and loading the excavation target on a loading target such as dump truck.Fig. 3 is a plan view ofwheel loader 1 performing an excavation-and-loading work.Fig. 3 showswheel loader 1 performing a so-called V-shape work. -
Fig. 3 (A) illustrateswheel loader 1 making a so-called empty-load advance.Wheel loader 1 travels forward along an excavation route R1 toward anexcavation target 310 such as soil, rocks, and sand.Wheel loader 1 pushesbucket 6 intoexcavation target 310 and stops traveling forward. An excavation work of scooping out at least a part ofexcavation target 310 withbucket 6 is performed, by liftingbucket 6 withcutting edge 6a (Fig. 1 ) ofbucket 6 being caught inexcavation target 310. -
Fig. 3 (B) illustrateswheel loader 1 making a so-called loaded retreat.Excavation target 310 is loaded as a load inbucket 6.Wheel loader 1 travels backward along excavation route R1 to the position where it started traveling forward inFig. 3 (A) . -
Fig. 3 (C) illustrateswheel loader 1 making a so-called loaded advance. With the load (excavation target 310) loaded inbucket 6,wheel loader 1 travels forward toward avessel 301 of adump truck 300.Wheel loader 1 travels forward along a loading route R2 from the position where it started traveling forward inFig. 3 (A) towarddump truck 300. Aswheel loader 1 approachesdump truck 300 and reaches a predetermined position,wheel loader 1 loads theload 310 inbucket 6 intovessel 301.Vessel 301 corresponds to one example of "load container" into which load 310 inbucket 6 is loaded. -
Fig. 3 (D) illustrateswheel loader 1 making a so-called empty-load retreat. In the state where all load 310 inbucket 6 has been discharged intovessel 301 ofdump truck 300 so that the inside ofbucket 6 is empty,wheel loader 1 travels backward along loading route R2 to the position where it started traveling forward inFig. 3 (C) . - Thus,
wheel loader 1 can repeatedly perform a series of operations: excavation, retreat, approaching the dump, discharging load, and retreat. - For automation of loading onto
dump truck 300 bywheel loader 1, it is desired to reproduce, under automatic control, an operation of work implement 3 for a loading work by a skilled operator, in order to preventload 310 placed invessel 301 from spilling fromvessel 301.Fig. 4 is a block diagram showing a configuration of an automatic control system ofwheel loader 1. - An
automation controller 100 is configured to be capable of transmitting and receiving signals to and fromvehicular body controller 50 described with reference toFig. 2 .Automation controller 100 is also configured to be capable of transmitting and receiving signals to and from an externalinformation acquisition unit 110. Externalinformation acquisition unit 110 includes asensing device 111 and a positioninformation acquisition device 112.Sensing device 111 and positioninformation acquisition device 112 are mounted onwheel loader 1. -
Sensing device 111 acquires information about the surroundings ofwheel loader 1. As shown inFig. 1 ,sensing device 111 is attached, for example, to an upper front surface ofcab 5.Sensing device 111 corresponds to one example of "object sensor" that detects an object around the main body ofwheel loader 1. -
Sensing device 111 detects the direction of an object outsidewheel loader 1 and the distance to the object in a non-contact manner.Sensing device 111 is, for example, LiDAR (Light Detection and Ranging) that emits laser light to obtain information about an object.Sensing device 111 may be a visual sensor including a camera.Sensing device 111 may be Radar (Radio Detection and Ranging) that acquires information about an object by emitting radio waves.Sensing device 111 may also be an infrared sensor. - Position
information acquisition device 112 acquires information about the current position ofwheel loader 1. Positioninformation acquisition device 112 acquires information about the position ofwheel loader 1 in a global coordinate system with respect to the earth, for example, by using a satellite positioning system. Positioninformation acquisition device 112 uses, for example, GNSS (Global Navigation Satellite Systems), and has a GNSS receiver. The satellite positioning system calculates the position ofwheel loader 1 by calculating the position of an antenna of the GNSS receiver based on positioning signals that the GNAA receiver has received from satellites. - External information about
wheel loader 1 acquired by sensingdevice 111 and position information aboutwheel loader 1 acquired by positioninformation acquisition device 112 are input toautomation controller 100. -
Vehicular body controller 50 is configured to be capable of transmitting and receiving signals to and from vehicleinformation acquisition unit 120, and receives input of information aboutwheel loader 1 acquired by vehicleinformation acquisition unit 120. Vehicleinformation acquisition unit 120 is constituted of various sensors mounted onwheel loader 1. Vehicleinformation acquisition unit 120 includes anarticulation angle sensor 121, avehicle speed sensor 122, aboom angle sensor 123, abucket angle sensor 124, and a boomcylinder pressure sensor 125. -
Articulation angle sensor 121 detects an articulation angle which is an angle formed betweenfront frame 2a andrear frame 2b, and generates a signal indicative of the detected articulation angle.Articulation angle sensor 121 outputs the signal indicative of the articulation angle tovehicular body controller 50. -
Vehicle speed sensor 122 detects the speed of movingwheel loader 1 by travel device 4 (Fig. 1 ) by detecting the rotational speed of the output shaft of transmission 23 (Fig. 2 ), for example, and generates a signal indicative of the detected vehicle speed.Vehicle speed sensor 122 outputs a signal indicative of the vehicle speed tovehicular body controller 50.Vehicle speed sensor 122 corresponds to one example of "travel sensor" that detects a traveling state of travel device 4 (travel unit). -
Boom angle sensor 123 is constituted, for example, of a rotary encoder provided on boom pin 9 which is a part forboom 14 to be attached tovehicular body frame 2.Boom angle sensor 123 detects the angle ofboom 14 with respect to the horizontal direction and generates a signal indicative of the detected angle ofboom 14.Boom angle sensor 123 outputs a signal indicative of the angle ofboom 14 tovehicular body controller 50. -
Bucket angle sensor 124 is constituted, for example, of a rotary encoder provided on asupport pin 18a which is a rotation shaft ofbell crank 18.Bucket angle sensor 124 detects the angle ofbucket 6 with respect toboom 14, and generates a signal indicative of the detected angle ofbucket 6.Bucket angle sensor 124 outputs the signal indicative of the angle ofbucket 6 tovehicular body controller 50. -
Boom angle sensor 123 andbucket angle sensor 124 correspond to one example of "work implement attitude sensor" that detects the attitude of work implement 3. The work implement attitude sensor may be an angle sensor that detects the angle of bell crank 18 and an angle sensor that detects the angle oflink 15, instead of or in addition toboom angle sensor 123 andbucket angle sensor 124. The work implement attitude sensor is not limited to the rotary encoder, and may be a stroke sensor, an IMU (Inertial Measurement Unit), a potentiometer, a visual sensor, or the like. - When the stroke sensor is used as the work implement attitude sensor, for example, the stroke sensor is attached to each of
boom cylinder 16 andbucket cylinder 19. The stroke amount of each ofcylinders boom 14 andbucket 6 can be detected from the stroke amounts. - When the IMU is used as the work implement attitude sensor, for example, the IMU is attached to each of
boom 14 andbucket 6. Each IMU detects angles (or angular velocities) and accelerations of the three axes. The attitudes ofboom 14 andbucket 6 can be detected from the angles (or angular velocities) and accelerations of the three axes detected by the IMU. - When the potentiometer is used as the work implement attitude sensor, for example, the potentiometer is attached to each of a vicinity of the
boom 14 side end ofboom cylinder 16 and a vicinity of the bell crank 18 side end ofbucket cylinder 19. Respective potentiometers can detect the rotation angle ofboom 14 with respect to the main body ofwheel loader 1 and the rotation angle ofbucket 6 with respect toboom 14. The attitude of work implement 3 can be detected from these rotation angles. - When the visual sensor is used as the work implement attitude sensor, respective states of
boom 14 andbucket 6 are imaged by the visual sensor. - Respective attitudes of
boom 14 andbucket 6 can be detected from information about the images captured by the visual sensor. The visual sensor is, for example, an imaging device such as camera. - Boom
cylinder pressure sensor 125 detects the pressure on the bottom side of boom cylinder 16 (boom bottom pressure) and generates a signal indicative of the detected boom bottom pressure. The boom bottom pressure increases whenbucket 6 is loaded with a load and decreases when the bucket is emptied. Boomcylinder pressure sensor 125 outputs the signal indicative of the boom bottom pressure tovehicular body controller 50. -
Vehicular body controller 50 outputs the information input from vehicleinformation acquisition unit 120 toautomation controller 100.Automation controller 100 receives detected values ofvehicle speed sensor 122,boom angle sensor 123, andbucket angle sensor 124 that are input throughvehicular body controller 50. - An
actuator 140 is configured to be capable of transmitting and receiving signals to and fromvehicular body controller 50.Actuator 140 is driven in response to a command signal fromvehicular body controller 50.Actuator 140 includes a brake EPC (electromagnetic proportional control valve) 141 for actuating a brake oftravel device 4, asteering EPC 142 for adjusting the travel direction ofwheel loader 1, a work implementEPC 143 for causing work implement 3 to operate, and an HMT (Hydraulic Mechanical Transmission) 144. - Electromagnetic
proportional control valves Fig. 2 constitute work implementEPC 143.Transmission 23 shown inFig. 2 is implemented asHMT 144 utilizing electronic control.Transmission 23 may be an HST (Hydro-Static Transmission). A power transmission device that transmits power fromengine 21 to runningwheels -
Vehicular body controller 50 includestransmission controller 70 and work implementcontroller 80.Transmission controller 70 includes abrake control unit 71 and anaccelerator control unit 72.Brake control unit 71 outputs a command signal for controlling actuation of the brake, to brakeEPC 141.Accelerator control unit 72 outputs a command signal for controlling the vehicle speed, toHMT 144. - Work implement
controller 80 includes asteering control unit 81 and a work implementcontrol unit 82.Steering control unit 81 outputs a command signal for controlling the travel direction ofwheel loader 1, tosteering EPC 142. Work implementcontrol unit 82 outputs a command signal for controlling operation of work implement 3, to work implementEPC 143. -
Automation controller 100 includes aposition estimation unit 101, apath planning unit 102, a routetracking control unit 103, and a loadpush determination unit 104. -
Position estimation unit 101 estimates the current position ofwheel loader 1 based on the position information acquired by positioninformation acquisition device 112.Position estimation unit 101 also recognizes a target position based on external information acquired by sensingdevice 111. The target position is, for example, the position ofexcavation target 310 or the position ofdump truck 300 shown inFig. 3 .Sensing device 111 may recognize the target position and input the target position toautomation controller 100, orposition estimation unit 101 may recognize the target position based on a detection result detected by sensingdevice 111. -
Path planning unit 102 generates an optimal route connecting the current position and the target position ofwheel loader 1. The optimum route includes a route of traveling bytravel device 4 and a route of operation of work implement 3. - Route
tracking control unit 103 controls the accelerator, the brake, and the steering so thatwheel loader 1 tracks the optimum route generated bypath planning unit 102. A command signal for causingwheel loader 1 to travel along the optimal route is output from route trackingcontrol unit 103 to brakecontrol unit 71,accelerator control unit 72, andsteering control unit 81. Routetracking control unit 103controls boom cylinder 16 andbucket cylinder 19 so that work implement 3 operates along the optimum route generated bypath planning unit 102. A command signal for moving work implement 3 along the optimal route is output from route trackingcontrol unit 103 to work implementcontrol unit 82. - An
interface 130 is configured to be capable of transmitting and receiving signals to and fromvehicular body controller 50.Interface 130 includes anautomation switch 131, an engineemergency stop switch 132, and amode lamp 133. -
Automation switch 131 is operated by an operator. The operator operatesautomation switch 131 to make a switch between manual operation ofwheel loader 1 and automatic control ofwheel loader 1. Engineemergency stop switch 132 is operated by an operator. When an event occurs that requires emergency stop ofengine 21, the operator operates engineemergency stop switch 132. Signals for operations ofautomation switch 131 and engineemergency stop switch 132 are input tovehicular body controller 50. -
Mode lamp 133 indicates whetherwheel loader 1 is currently in a mode of being manually operated by an operator or in an automatically controlled mode. A command signal for controlling lighting of the lamp is output fromvehicular body controller 50 tomode lamp 133. - The automatic control system of
wheel loader 1 acquires information about a loading status (for example, load condition) of a load invessel 301 for automating a load push in a loading work. The automatic control system ofwheel loader 1 also detects information about the loading status of the load invessel 301. The automatic control system ofwheel loader 1 moves (pushes) the load invessel 301 by causingwheel loader 1 to operate based on the detected information. Thus, the automatic control system ofwheel loader 1 includes a "loading sensor" that detects information about the loading status of the load invessel 301. - The "loading sensor" detects information about a loading status of
load 310 invessel 301. The loading sensor may include, for example, at least one of the "object sensor" and the "work implement attitude sensor" described above. That is, the loading sensor may be the "object sensor" alone, or the "work implement attitude sensor" alone, or may include both the "object sensor" and the "work implement attitude sensor." - When the loading sensor is the object sensor, a signal indicating the loading status of
load 310 invessel 301 detected by the object sensor serves as information about the loading status ofload 310 invessel 301. In this case, the loading status ofload 310 invessel 301 is detected by sensingdevice 111, which is one example of the object sensor. Specifically, the loading status ofload 310 invessel 301 is detected by any one or any combination of a LiDAR, a visual sensor, a Radar, an infrared sensor, and the like, which are each an example ofsensing device 111. - When the loading sensor is the work implement attitude sensor, a signal indicating the attitude of work implement 3 detected by the work implement attitude sensor serves as information about the loading status of
load 310 invessel 301. In this case, a signal indicating the attitude of work implement 3 is detected by any one or any combination of a rotary encoder, a stroke sensor, an IMU, a potentiometer, a visual sensor, and the like, which are each an example of the work implement attitude sensor. - The automatic control system of
wheel loader 1 includes loadpush determination unit 104 that determines whether or not it is necessary to pushload 310 invessel 301, based on the information about the loading status ofload 310 invessel 301. Loadpush determination unit 104 is included inautomation controller 100. - Load
push determination unit 104 determines whether or not it is necessary to pushload 310 invessel 301, based on the information detected by the loading sensor. When the information about the loading status is detected by the object sensor alone, loadpush determination unit 104 determines whether or not it is necessary to pushload 310 invessel 301, based on the information about the loading status ofload 310 invessel 301 acquired by sensingdevice 111, for example. - In this case,
automation controller 100 has stored, for example, relationship data indicating a relationship between the loading status ofload 310 invessel 301 and whether it is necessary to push the load. Loadpush determination unit 104 determines whether or not it is necessary to moveload 310 invessel 301, by comparing the relationship data with the information about the loading status ofload 310 invessel 301 acquired by sensingdevice 111. - When the information about the loading status is detected by the work implement attitude sensor alone, load
push determination unit 104 calculates the number of times load 310 has been loaded intovessel 301 by work implement 3, from a signal indicating the attitude of work implement 3 acquired by the work implement attitude sensor, for example. When the calculated number of times of loading is equal to or more than a predetermined number of times (for example, two), loadpush determination unit 104 determines that it is necessary topushy load 310 invessel 301. In this case, the signal indicating the number of times of loading corresponds to the information about the loading status ofload 310 invessel 301. - It should be noted that the information about the loading status may be detected by both the object sensor and the work implement attitude sensor. In this case, it is determined whether or not it is necessary to push
load 310 invessel 301, based on both the information about the loading status detected by the object sensor and the information about the loading status detected by the work implement attitude sensor. - When load
push determination unit 104 determines that it is necessary to pushload 310 invessel 301,automation controller 100 causeswheel loader 1 to operate so as to pushload 310 toward center CL ofvessel 301. - Specifically, when load
push determination unit 104 determines that it is necessary to pushload 310 invessel 301,path planning unit 102 generates a route for causingwheel loader 1 to operate so as to moveload 310 toward center CL ofvessel 301. Then, route trackingcontrol unit 103 controls the accelerator, the brake, the steering,boom cylinder 16, andbucket cylinder 19, so thatwheel loader 1 tracks the route generated bypath planning unit 102 and work implement 3 operates. -
Fig. 5 is a flowchart showing a flow of an operation of loading, onto a loading target, a load loaded onbucket 6, by automatically controllingwheel loader 1. - As shown in
Fig. 5 , in step S100, the shape ofvessel 301 ofdump truck 300, which is a loading target on which a load is to be loaded, is recognized in advance before a loading work is started. For example, the shape ofdump truck 300 is acquired by a LiDAR, which is sensingdevice 111. Laser light is applied from the LiDAR to dumptruck 300 to acquire point group data indicating three-dimensional coordinate values of measurement points ondump truck 300.Dump truck 300 is sensed from the front, rear, right, and left sides, so that the shape ofvessel 301 can be recognized from the point group information. The recognized shape ofvessel 301 is input toautomation controller 100. - In step S101,
sensing device 111 recognizes a reference point P (Fig. 7 ) ofdump truck 300. For example, the LiDAR, which is sensingdevice 111, senses dumptruck 300.Automation controller 100 recognizes the position ofvessel 301 by comparing the point group detected by sensingdevice 111 with a master point group indicating the shape ofvessel 301.Automation controller 100 sets reference point P at an upper end of a side surface ofvessel 301 ofdump truck 300 recognized by the LiDAR, which is sensingdevice 111. - In step S102,
automation controller 100 sets coordinates of target positions c, d, and e (Fig. 7 ) ofcutting edge 6a ofbucket 6 moved by automatic control, with respect to reference pointP. Cutting edge 6a ofbucket 6 corresponds to one example of "feature point" set on work implement 3. The feature point is not limited to cuttingedge 6a ofbucket 6, and any of other points on work implement 3 may be set as the feature point. - Reference point P and target positions c, d, and e are now described.
Fig. 7 is a diagram schematically showing an arrangement ofvessel 301 andwheel loader 1 at the start of approaching a dump. InFig. 7 and subsequentFigs. 8 to 10 ,vessel 301 as seen in the front-rear direction ofdump truck 300 is schematically shown, and a part of a front portion ofwheel loader 1 approachingvessel 301 from the left side or the right side ofdump truck 300 is schematically shown. - Target position c is set as a position through which
cutting edge 6a ofbucket 6 passes whilewheel loader 1 is traveling forward towarddump truck 300. During the forward travel ofwheel loader 1, an operation of work implement 3 for movingbucket 6 in the dumping direction is performed in order to load theload 310 inbucket 6 intovessel 301. The position at thetime cutting edge 6a ofbucket 6 performing dumping during a loading operation is located at the lowermost position is target position c. - Target position d is set as a position through which
cutting edge 6a ofbucket 6 passes after passing through target position c. Target position d is set closer to reference point P than target position c. Target position d is a position at which the operation ofbucket 6 in the dumping direction is stopped. When cuttingedge 6a ofbucket 6 is located at target position d,bucket 6 is in a full dump state, for example. When cuttingedge 6a ofbucket 6 is at target position d, the length ofbucket cylinder 19 is minimum. Target position d is located abovevessel 301. - When load
push determination unit 104 determines that it is necessary to pushload 310 which has been loaded invessel 301, target position d is a position at which load push is started. Target position d is a position at which the operation of work implement 3 is stopped whilebucket 6 is maintained in the full dump state, for example. - Target position e is set as a position through which
cutting edge 6a ofbucket 6 passes after passing through target position d. Target position e is set farther from reference point P than target position d. From target position d to target position e, the state in which the operation of work implement 3 is stopped is maintained in the state in whichbucket 6 is in the full dump state, for example, and the forward travel ofwheel loader 1 is continued. Target position e is located abovevessel 301. - As shown in
Fig. 7 , an xy coordinate system having reference point P as the origin is defined. The x-axis is the left-right direction ofdump truck 300 through reference point P. The direction away fromvessel 301 with respect to reference point P is +x direction. The y-axis is the top-bottom direction through reference point P. The upward direction from reference point P is +y direction. - A bucket angle θ shown in
Fig. 7 is an angle formed by the ground and backsurface 6b ofbucket 6. Bucket angle θ may also be an angle formed byback surface 6b ofbucket 6 and a horizontal plane with respect to the vehicular body. - Target positions c, d, and e are determined by giving respective positions of cutting
edge 6a ofbucket 6 in the horizontal direction and the vertical direction with respect to reference point P, that is, the x-coordinate and the y-coordinate. Target position c is set as a position at which the height position of cuttingedge 6a is the lowest (the y-coordinate has the minimum value) while dischargingload 310 frombucket 6. Target position c is set to a position where the y-coordinate is on the negative side. The y-coordinates of target positions d and e are set to positions on the positive side. - Target positions c, d, and e are set at respective positions having respective x-coordinates on the negative side. Target positions d and e are set at the same y-coordinate, for example. At target positions d and e,
bucket 6 may not be in the full dump state, but may be in a dump state in which load 310 inbucket 6 can be loaded intovessel 301. Moreover, target positions d and e may not be at the same y-coordinate, and target position e may be a position (position in the -y direction) lower than target position d. - Bucket angle θ at the
time cutting edge 6a ofbucket 6 is located at each target position is also set. The attitude of work implement 3 at thetime cutting edge 6a ofbucket 6 is located at each target position is determined from the x-coordinate and the y-coordinate of each target position and bucket angle θ at each target position.Automation controller 100 stores the attitude (target attitude) of work implement 3 at thetime cutting edge 6a ofbucket 6 is located at each target position. The length ofboom cylinder 16 and the length ofbucket cylinder 19 at thetime cutting edge 6a ofbucket 6 is located at each target position are determined, based on the target attitude at thetime cutting edge 6a ofbucket 6 is located at the target position. - The x-coordinate and the y-coordinate of each target position and bucket angle θ at each target position can be determined by analyzing the trajectory of cutting
edge 6a while a skilled operator performs a loading work, extracting a characteristic position, and extracting the attitude of work implement 3 at the characteristic position. -
Fig. 8 is a diagram schematically showing an attitude of the wheel loader at the time the cutting edge of the bucket is located at the lowermost position during a loading operation.Fig. 9 is a diagram schematically showing an attitude of the wheel loader at the start of load push.Fig. 10 is a diagram schematically showing an attitude of the wheel loader at the time load push is ended. InFig. 8 , cuttingedge 6a ofbucket 6 is located at target position c. InFig. 9 , cuttingedge 6a is located at target position d. InFig. 10 , cuttingedge 6a is located at target position e. -
Fig. 11 is a graph showing change of the cylinder length during a loading work. The horizontal axis ofFig. 11 represents elapse of time, and auxiliary lines are drawn at respective times at whichcutting edge 6a passes through target positions c, d, and e. The vertical axis inFig. 11 represents the length ofboom cylinder 16 andbucket cylinder 19. - As shown in
Fig. 11 andFigs. 7 and8 ,wheel loader 1 is traveling forward before cuttingedge 6a reaches target position c. The length ofboom cylinder 16 is increasing and accordingly boom 14 is rising. The length ofbucket cylinder 19 continues decreasing, so thatbucket 6 continues moving in the dumping direction. At thetime cutting edge 6a reaches target position c, cuttingedge 6a is located at the lowermost position during the loading operation. - As shown in
Fig. 11 andFigs. 8 and 9 , while cuttingedge 6a moves from target position c to target position d,wheel loader 1 continues traveling forward. The length ofboom cylinder 16 is still increasing and accordingly boom 14 is still rising. The length ofbucket cylinder 19 is still decreasing, so thatbucket 6 continues moving in the dumping direction. At thetime cutting edge 6a reaches target position d,bucket 6 assumes the attitude in the full dump state. At thetime cutting edge 6a reaches target position d,bucket cylinder 19 has the minimum length. - As shown in
Fig. 11 andFigs. 9 and10 , while cuttingedge 6a moves from target position d to target position e,wheel loader 1 continues traveling forward. While cuttingedge 6a moves from target position d to target position e, the operation of work implement 3 is stopped. Therefore, the length ofboom cylinder 16 and the length ofbucket cylinder 19 are identical respectively to the length ofboom cylinder 16 and the length ofbucket cylinder 19 at target position d. Thus, at thetime cutting edge 6a reaches target position e,bucket 6 maintains the attitude in the full dump state andbucket cylinder 19 has the minimum length. - As shown in
Fig. 11 , at thetime cutting edge 6a reaches target position e,wheel loader 1 is switched from forward travel to backward travel. While cuttingedge 6a moves after reaching target position e, the operation of work implement 3 may be stopped for a predetermined time. In this case, during a predetermined time after reaching target position e, the length ofboom cylinder 16 and the length ofbucket cylinder 19 are identical respectively to the length ofboom cylinder 16 and the length ofbucket cylinder 19 at target position e. - Moreover, after a predetermined time has elapsed from the time target position e is reached,
wheel loader 1 may continue the backward travel, the length ofboom cylinder 16 may be decreased (boom 14 may be lowered), and the length ofbucket cylinder 19 may be increased (bucket 6 may be moved in the tilt direction). - As described above, cutting
edge 6a ofbucket 6 can be moved to pass through target positions c and d in this order, to dischargeload 310 from withinbucket 6 intovessel 301. Moreover, cuttingedge 6a ofbucket 6 can be moved to pass through target positions d and e in this order, to pushload 310 invessel 301 bybucket 6. For example, load 310 invessel 301 can be pushed toward center CL ofvessel 301 bybucket 6. Thus, automatic control for movingbucket 6 can be applied towheel loader 1 to perform the operation ofwheel loader 1, including the load discharging operation and the load push operation that are equivalent to operations performed under operation of a skilled operator. - Referring again to
Fig. 5 , the description of the loading work under automatic control is continued. In step S103,automation controller 100 recognizes respective current positions ofwheel loader 1 and work implement 3. By acquiring the current position of the vehicular body ofwheel loader 1 by means of positioninformation acquisition device 112 and acquiring the attitude of the work implement with respect to the vehicular body by means ofboom angle sensor 123 and thebucket angle sensor 124, respective current positions ofwheel loader 1 and work implement 3 in the global coordinate system can be recognized. The relative position of cuttingedge 6a ofbucket 6 with respect tovessel 301 ofdump truck 300 can be calculated based on the current positions ofwheel loader 1 and work implement 3 and the current position ofdump truck 300 in the global coordinate system. - Alternatively,
sensing device 111 may be used to acquire the direction and the distance of reference point P ofvessel 301 ofdump truck 300 with respect to the position wheresensing device 111 is arranged, to calculate the current relative position of cuttingedge 6a ofbucket 6 with respect to reference point P. - The position of cutting
edge 6a ofbucket 6 with respect to each of target positions c to e is recognized from the current position of work implement 3. For example, it is recognized that cuttingedge 6a has not yet reached target position c, or that cuttingedge 6a has passed through target position c and is located between target position c and target position d, or that cuttingedge 6a has passed through target position d and is located between target position d and target position e. Further, a target position toward whichcutting edge 6a is moved next is recognized. For example, if cuttingedge 6a has not yet reached target position c, it is recognized that the next target position is target position c; if cuttingedge 6a is located between target position c and target position d, it is recognized that the next target position is target position d; and if cuttingedge 6a is located between target position d and target position e, it is recognized that the next target position is target position e. - In step S104,
automation controller 100 recognizes the length ofboom cylinder 16 and the length ofbucket cylinder 19 at the current position.Boom angle sensor 123 detects the angle ofboom 14.Bucket angle sensor 124 detects the angle ofbucket 6. The attitude of work implement 3 is determined from the angle ofboom 14 and the angle ofbucket 6. The length ofboom cylinder 16 and the length ofbucket cylinder 19 at the current position are recognized based on the attitude of work implement 3. - Instead of or in addition to
boom angle sensor 123 andbucket angle sensor 124, an angle sensor for detecting the angle of the bell crank 18 and an angle sensor for detecting the angle oflink 15 may be provided. Instead of or in addition to the angle sensors, a stroke sensor, an IMU, a potentiometer, a visual sensor, or the like may detect the attitude of work implement 3. - In step S105,
automation controller 100 calculates the differences between the length ofboom cylinder 16 and the length ofbucket cylinder 19 at the current position recognized in step S104, and the length ofboom cylinder 16 and the length ofbucket cylinder 19 at the target position toward whichcutting edge 6a is moved next (referred to as the target cylinder length hereinafter).Automation controller 100 calculates the distance to movecylinders edge 6a to reach the next target position. - In step S106,
automation controller 100 refers to the current vehicle speed and determines a target cylinder stroke speed at which the target cylinder length is obtained when cuttingedge 6a reaches the next target position. When cuttingedge 6a reaches the next target position,automation controller 100controls boom cylinder 16 andbucket cylinder 19 so that work implement 3 takes the target attitude corresponding to the target position. The current vehicle speed is acquired byvehicle speed sensor 122. From the current position of cuttingedge 6a and the current vehicle speed, the time required to reach the next target position is calculated. The target cylinder stroke speed is determined by dividing the difference in cylinder length calculated in step S105 by the time taken to reach the next target position. - The cylinder stroke amount while
wheel loader 1 travels a unit distance may be determined. The fact thatwheel loader 1 has traveled a unit distance may be obtained from the vehicle speed or may be detected by sensingdevice 111. - In step S107,
automation controller 100 outputs, tovehicular body controller 50, a command current corresponding to the target cylinder stroke speed.Automation controller 100 outputs, to work implementcontrol unit 82 of work implementcontroller 80, a command to expand andcontract boom cylinder 16 andbucket cylinder 19 at the target cylinder stroke speed. The command to expand andcontract boom cylinder 16 andbucket cylinder 19 at the target cylinder stroke speed is output from work implementcontrol unit 82 to work implementEPC 143. - In step S108, work implement
EPC 143 that has received the command signal adjusts the opening degree to cause appropriate hydraulic oil to be supplied toboom cylinder 16 andbucket cylinder 19. Thus,boom cylinder 16 andbucket cylinder 19 operate. - In step S109,
automation controller 100 recognizes respective current lengths ofboom cylinder 16 andbucket cylinder 19, similarly to step S104.Automation controller 100 determines whether the respective current lengths ofboom cylinder 16 andbucket cylinder 19 have reached the target cylinder length. - When it is determined in step S109 that the target cylinder length has been reached (YES in step S109), the flow proceeds to step S110, and
automation controller 100 determines whether or not there is a next target position. - When it is determined in step S109 that the target cylinder length has not been reached (NO in step S109) and it is determined in step S110 that there is a next target position (YES in step S110), the flow returns to step S103 and the process of expanding and
contracting boom cylinder 16 andbucket cylinder 19 is repeated based on the current position of work implement 3. The cylinder speed is sequentially changed depending on the current position of cuttingedge 6a ofbucket 6. When the current position of cuttingedge 6a deviates from the position based on the cylinder speed set in the previous process, the cylinder speed is adjusted. - When it is determined in step S110 that there is no next target position (NO in step S110), the loading work is ended. In the present embodiment, this condition corresponds to the fact that the next target position is not set after target position d is reached.
- Next, an automatic control flow of load push is described with reference to
Fig. 6 for example. -
Fig. 6 is a flowchart showing automatic control of load push. By the automatic control of the automatic dumping illustrated inFig. 5 , cuttingedge 6a ofbucket 6 reaches target position d as shown inFig. 9 . Whether or not cuttingedge 6a has reached target position d is determined byautomation controller 100 based on whether or not respective lengths ofboom cylinder 16 andbucket cylinder 19 have reached the target length for target position d in the automatic control flow ofFig. 5 . At the time target position d is reached,bucket 6 has become the full dump state. Therefore, the operation for loading theload 310 inbucket 6 intovessel 301 is ended (step S201,Fig. 6 ). -
Automation controller 100 has acquired information about the loading status ofload 310 invessel 301. When cuttingedge 6a ofbucket 6 reaches target position d,automation controller 100 determines whether to pushload 310 in vessel 301 (step S202,Fig. 6 ). The acquisition of the information about the loading status and the determination as to whether or not it is necessary to push the load are performed by loadpush determination unit 104 ofautomation controller 100. - Load
push determination unit 104 determines whether it is necessary to pushload 310 invessel 301, based on the information about the loading status ofload 310 invessel 301. Loadpush determination unit 104 determines whether it is necessary to pushload 310 invessel 301, based on the information about the loading status ofload 310 invessel 301 acquired by sensingdevice 111, for example. - In this case,
automation controller 100 has stored relationship data indicating a relationship between the loading status ofload 310 invessel 301 and whether it is necessary to push the load. Loadpush determination unit 104 determines whether it is necessary to pushload 310 invessel 301, by comparing the relationship data with the information about the loading status ofload 310 invessel 301 acquired by sensingdevice 111. - Moreover, load
push determination unit 104 calculates the number of times load 310 has been loaded intovessel 301 by work implement 3, from a signal indicating the attitude of work implement 3 acquired by a work implement attitude sensor, for example. When the calculated number of times of loading is equal to or more than a predetermined number of times (for example, two), loadpush determination unit 104 determines that it is necessary to pushload 310 invessel 301. - In step S202, when load
push determination unit 104 determines that it is necessary to pushload 310 invessel 301,path planning unit 102 generates a route along whichwheel loader 1 is to be operated, so that cuttingedge 6a moves from target position d to target position e. - Route
tracking control unit 103 controls the accelerator, the brake, and the steering so thatwheel loader 1 tracks the route generated bypath planning unit 102. A command signal for causingwheel loader 1 to travel along an optimal route is output from route trackingcontrol unit 103 to brakecontrol unit 71,accelerator control unit 72, andsteering control unit 81. Thus,wheel loader 1 is controlled to travel forward from target position d to target position e, by route trackingcontrol unit 103. - Moreover, route tracking
control unit 103controls boom cylinder 16 andbucket cylinder 19 so that work implement 3 operates along the optimum route generated bypath planning unit 102. A command signal to move work implement 3 along the optimal route is output from route trackingcontrol unit 103 to work implementcontrol unit 82. Thus, work implement 3 is controlled by route trackingcontrol unit 103 to stop its operation from target position d to target position e. - Thus, route tracking
control unit 103 performs control to causewheel loader 1 to travel forward and cause work implement 3 to stop its operation, until target position e is reached from target position d (step S203,Fig. 6 ). Accordingly,wheel loader 1 is operated to pushload 310 invessel 301 toward center CL ofvessel 301. When cuttingedge 6a reaches target position e, the load push control is ended. - When load
push determination unit 104 determines in step S202 that it is not necessary to pushload 310 invessel 301, the load push control is ended. - Next, movement of the load in
vessel 301 by the load push is described with reference toFig. 12 (A) to Fig. 12 (C) . - As shown in
Fig. 12 (A) , aload 310A is loaded invessel 301 by loading performed for the first time, and aload 310B is loaded in the vessel by loading performed for the second time. For example, at the time the second loading is completed, load 310 loaded invessel 301 may be unbalanced. - If the loading status (load condition) of
load 310 invessel 301 is inappropriate as described above, there is a possibility that load 310 spills fromvessel 301 whiledump truck 300 is traveling. In order to preventload 310 from spilling fromvessel 301,bucket 6 moves load 310 invessel 301 toward center CL ofvessel 301 in the present embodiment. Thus, in the present embodiment, the control of load push bybucket 6 is performed after the second loading ofload 310B is completed, for example. - As shown in
Fig. 12 (B) , the load push is performed by movingcutting edge 6a ofbucket 6 from the end ofvessel 301 toward center CL. In this way, load 310 invessel 301 is pushed bybucket 6 to move to center CL ofvessel 301. - As shown in
Fig. 12 (C) , at thetime cutting edge 6a reaches target position e, the unbalance ofload 310 invessel 301 has been improved. This preventsload 310 from spilling fromvessel 301 whiledump truck 300 is traveling. - After cutting
edge 6a reaches target position e,wheel loader 1 travels backward. Thus,bucket 6 moves backward away fromdump truck 300 while forming an apex of 310. - It should be noted that center CL of
vessel 301 refers to the center ofvessel 301 in the width direction in a cross section ofvessel 301 in the direction in whichwheel loader 1 travels forward towardvessel 301 during the loading operation (in the cross section shown inFig. 12 (A) to (C) ). - The following is a summary of characteristic configurations, functions and effects of the present embodiment, a part of which has already been described above.
- In the present embodiment, automation controller 100 (load push determination unit 104) shown in
Fig. 4 acquires information about the loading status ofload 310 invessel 301. Automation controller 100 (load push determination unit 104) also determines whether or not it is necessary to pushload 310 invessel 301, based on the information about the loading status ofload 310 invessel 301. When automation controller 100 (load push determination unit 104) determines that it is necessary to moveload 310 invessel 301, automation controller 100 (load push determination unit 104) operateswheel loader 1 to moveload 310 toward center CL ofvessel 301. - Thus, load 310 is pushed toward center CL of
vessel 301, based on the loading status ofload 310 invessel 301. Therefore, unbalance ofload 310 invessel 301 is improved. This preventsload 310 from spilling fromvessel 301 whiledump truck 300 is traveling. - In the present embodiment, when automation controller 100 (load push determination unit 104) shown in
Fig. 4 determines it is necessary to moveload 310 invessel 301, automation controller 100 (load push determination unit 104) operateswheel loader 1 to moveload 310 toward center CL ofvessel 301 by causingtravel device 4 to travel forward. Accordingly, it is possible to causebucket 6 to pushload 310 invessel 301 toward center CL ofvessel 301. - In the present embodiment, when automation controller 100 (load push determination unit 104) shown in
Fig. 4 determines it is necessary to moveload 310 invessel 301, automation controller 100 (load push determination unit 104) causestravel device 4 to travel forward while stopping driving the work implement actuator, to thereby operatewheel loader 1 to moveload 310 toward center CL ofvessel 301. Accordingly, operation control of the work implement actuator while the load is pushed is unnecessary, which makes it possible to simplify operation control. - In the present embodiment, when automation controller 100 (load push determination unit 104) shown in
Fig. 4 determines it is necessary to moveload 310 invessel 301, automation controller 100 (load push determination unit 104) operateswheel loader 1 to moveload 310 toward center CL ofvessel 301 by causingtravel device 4 to travel forward while keeping the height ofbucket 6. This eliminates the need to control the height ofbucket 6 while the load is pushed, which makes it possible to simplify operation control. - In the present embodiment, automation controller 100 (load push determination unit 104) shown in
Fig. 4 calculates the number of times loading intovessel 301 by work implement 3 is performed, based on the attitude of work implement 3 detected by the work implement attitude sensor, and determines whether or not it is necessary to moveload 310 invessel 301, based on the calculated number of times of loading. This makes it possible to easily determine whether or not it is necessary to push the load, based on the number of times of loading. - In the present embodiment, automation controller 100 (load push determination unit 104) shown in
Fig. 4 determines whether or not it is necessary to moveload 310 invessel 301, based on the loading status ofload 310 detected by the object sensor. Accordingly, it can be determined whether or not it is necessary to push the load, in accordance with the actual loading status ofload 310 invessel 301. It is therefore possible to more accurately preventload 310 from spilling fromvessel 301 whiledump truck 300 is traveling. - The foregoing includes features described in the following.
- A work machine including:
- a main body;
- a work implement that is attached to the main body and loads a load into a load container;
- a work implement actuator that drives the work implement with respect to the main body; and
- a controller that commands the work implement actuator to drive, based on a detected value of a position of the work implement and a detected value of a position of the load container with respect to the work machine, wherein
- the controller acquires information about a loading status of the load in the load container, determines whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load, and operates, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- The work machine according to
Appendix 1, wherein - the main body includes a travel unit,
- the work machine further includes a travel sensor that detects a traveling state of the travel unit, and
- the controller commands the work implement actuator to drive, based on a detected value of the travel sensor and the detected value of the position of the load container with respect to the work machine.
- The work machine according to
Appendix 2, wherein when the controller determines that it is necessary to move the load in the load container, the controller operates the work machine to move the load toward the center of the load container by causing the travel unit to travel forward. - The work machine according to
Appendix 3, wherein when the controller determines that it is necessary to move the load in the load container, the controller operates the work machine to move the load toward the center of the load container by causing the travel unit to travel forward while stopping the work implement actuator from driving. - The work machine according to
Appendix 3 orAppendix 4, wherein - the work implement includes a bucket, and
- when the controller determines that it is necessary to move the load in the load container, the controller operates the work machine to move the load toward the center of the load container by causing the travel unit to travel forward while keeping a height of the bucket.
- The work machine according to any one of
Appendix 1 toAppendix 5, further including a work implement attitude sensor that detects an attitude of the work implement, for determining the loading status of the load, wherein
the controller calculates the number of times the work implement has performed loading into the load container, based on the attitude of the work implement detected by the work implement attitude sensor, and determines whether it is necessary to move the load in the load container, based on the calculated number of times. - The work machine according to any one of
Appendix 1 toAppendix 5, further including an object sensor that detects the loading status of the load loaded into the load container, for determining the loading status of the load, wherein
the controller determines whether it is necessary to move the load in the load container, based on the loading status of the load detected by the object sensor. - A system including a work machine, the system including:
- a work machine main body;
- a work implement that is attached to the work machine main body and loads a load into a load container;
- a work implement actuator that drives the work implement with respect to the work machine main body; and
- a controller that commands the work implement actuator to drive, based on a detected value of a position of the work implement and a detected value of a position of the load container with respect to the work machine, wherein
- the controller acquires information about a loading status of the load in the load container, determines whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load, and operates, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- A method for controlling a work machine, the method including:
- acquiring information about a loading status of a load in a load container;
- determining whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load; and
- operating, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- It should be construed that the embodiments disclosed herein are given by way of illustration in all respects, not by way of limitation. It is intended that the scope of the present invention is defined by claims, not by the description above, and encompasses all modifications and variations equivalent in meaning and scope to the claims.
- 1 wheel loader; 2 vehicular body frame; 2a front frame; 2b rear frame; 3 work implement; 4 travel device; 4a, 4b running wheel; 5 cab; 6 bucket; 6a cutting edge; 6b back surface; 8 operation device; 9 boom pin; 11 steering cylinder; 13 work implement pump; 14 boom; 15 link; 16 boom cylinder; 17 bucket pin; 18 bell crank; 18a support pin; 18b, 18c coupling pin; 19 bucket cylinder; 21 engine; 23 transmission; 25 axle; 32 main valve; 35, 36 electromagnetic proportional control valve; 41 accelerator pedal; 42 work implement operation lever; 50 vehicular body controller; 51 machine monitor; 60 engine controller; 70 transmission controller; 71 brake control unit; 72 accelerator control unit; 80 work implement controller; 81 steering control unit; 82 work implement control unit; 100 automation controller; 101 position estimation unit; 102 path planning unit; 103 route tracking control unit; 104 determination unit; 110 external information acquisition unit; 111 sensing device; 112 position information acquisition device; 120 vehicle information acquisition unit; 121 articulation angle sensor; 122 vehicle speed sensor; 123 boom angle sensor; 124 bucket angle sensor; 125 boom cylinder pressure sensor; 130 interface; 131 automation switch; 132 engine emergency stop switch; 133 mode lamp; 140 actuator; 141 brake EPC; 142 steering EPC; 143 work implement EPC; 144 HMT; 300 dump truck; 301 vessel; 310 load (excavation target).
Claims (9)
- A work machine comprising:a main body;a work implement that is attached to the main body and loads a load into a load container;a work implement actuator that drives the work implement with respect to the main body; anda controller that commands the work implement actuator to drive, based on a detected value of a position of the work implement and a detected value of a position of the load container with respect to the work machine, whereinthe controller acquires information about a loading status of the load in the load container, determines whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load, and operates, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- The work machine according to claim 1, whereinthe main body includes a travel unit,the work machine further comprises a travel sensor that detects a traveling state of the travel unit, andthe controller commands the work implement actuator to drive, based on a detected value of the travel sensor and the detected value of the position of the load container with respect to the work machine.
- The work machine according to claim 2, wherein when the controller determines that it is necessary to move the load in the load container, the controller operates the work machine to move the load toward the center of the load container by causing the travel unit to travel forward.
- The work machine according to claim 3, wherein when the controller determines that it is necessary to move the load in the load container, the controller operates the work machine to move the load toward the center of the load container by causing the travel unit to travel forward while stopping the work implement actuator from driving.
- The work machine according to claim 3, whereinthe work implement includes a bucket, andwhen the controller determines that it is necessary to move the load in the load container, the controller operates the work machine to move the load toward the center of the load container by causing the travel unit to travel forward while keeping a height of the bucket.
- The work machine according to claim 1, further comprising a work implement attitude sensor that detects an attitude of the work implement, for determining the loading status of the load, wherein
the controller calculates the number of times the work implement has performed loading into the load container, based on the attitude of the work implement detected by the work implement attitude sensor, and determines whether it is necessary to move the load in the load container, based on the calculated number of times. - The work machine according to claim 1, further comprising an object sensor that detects the loading status of the load loaded into the load container, for determining the loading status of the load, wherein
the controller determines whether it is necessary to move the load in the load container, based on the loading status of the load detected by the object sensor. - A system comprising a work machine, the system comprising:a work machine main body;a work implement that is attached to the work machine main body and loads a load into a load container;a work implement actuator that drives the work implement with respect to the work machine main body; anda controller that commands the work implement actuator to drive, based on a detected value of a position of the work implement and a detected value of a position of the load container with respect to the work machine, whereinthe controller acquires information about a loading status of the load in the load container, determines whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load, and operates, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
- A method for controlling a work machine, the method comprising:acquiring information about a loading status of a load in a load container;determining whether it is necessary to move the load in the load container, based on the acquired information about the loading status of the load; andoperating, when determining that it is necessary to move the load in the load container, the work machine to move the load toward a center of the load container.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2022141480A JP2024036922A (en) | 2022-09-06 | 2022-09-06 | Work machines, systems including work machines, and control methods for work machines |
| PCT/JP2023/030884 WO2024053443A1 (en) | 2022-09-06 | 2023-08-28 | Work machine, system including work machine, and method for controlling work machine |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP4545710A1 true EP4545710A1 (en) | 2025-04-30 |
| EP4545710A4 EP4545710A4 (en) | 2026-07-01 |
Family
ID=90191098
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP23862982.8A Pending EP4545710A4 (en) | 2022-09-06 | 2023-08-28 | WORK MACHINE, SYSTEM WITH THE WORK MACHINE AND METHOD FOR CONTROLLING THE WORK MACHINE |
Country Status (4)
| Country | Link |
|---|---|
| EP (1) | EP4545710A4 (en) |
| JP (1) | JP2024036922A (en) |
| CN (1) | CN119522305A (en) |
| WO (1) | WO2024053443A1 (en) |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE19858401A1 (en) * | 1997-12-19 | 1999-09-09 | Univ Carnegie Mellon | Loading strategy using sight feedback, e.g. for earth-moving machines |
| WO2015129932A1 (en) | 2015-03-25 | 2015-09-03 | 株式会社小松製作所 | Wheel loader |
| CN114174596B (en) * | 2019-09-18 | 2024-03-08 | 住友重机械工业株式会社 | Excavator |
| JP7484630B2 (en) * | 2020-09-29 | 2024-05-16 | コベルコ建機株式会社 | Loading point determination system |
-
2022
- 2022-09-06 JP JP2022141480A patent/JP2024036922A/en active Pending
-
2023
- 2023-08-28 WO PCT/JP2023/030884 patent/WO2024053443A1/en not_active Ceased
- 2023-08-28 EP EP23862982.8A patent/EP4545710A4/en active Pending
- 2023-08-28 CN CN202380055842.4A patent/CN119522305A/en active Pending
Also Published As
| Publication number | Publication date |
|---|---|
| CN119522305A (en) | 2025-02-25 |
| WO2024053443A1 (en) | 2024-03-14 |
| EP4545710A4 (en) | 2026-07-01 |
| JP2024036922A (en) | 2024-03-18 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP3851590B1 (en) | System and method of controlling wheel loader | |
| US20260015818A1 (en) | System including work machine, work machine controller, and method of controlling work machine | |
| US11454007B2 (en) | Control system for work vehicle, method, and work vehicle | |
| EP4506509A1 (en) | Work machine, system including work machine, and method for controlling work machine | |
| EP4545711A1 (en) | System including work machine, for work machine controller, and method of controlling work machine | |
| WO2024176867A1 (en) | Work machine-including system, work machine controller, and work machine path generation method | |
| EP4506508A1 (en) | Work machine, system including work machine, and method for controlling work machine | |
| JP2024036922A (en) | Work machines, systems including work machines, and control methods for work machines | |
| EP4545713A1 (en) | System including work machine and method of controlling work machine | |
| EP4610440A1 (en) | System including work machine, method for controlling work machine, and controller for work machine | |
| EP4603643A1 (en) | System including work machine, control method of work machine, and controller of work machine | |
| EP4603644A1 (en) | System including work machine, method for controlling work machine, and controller for work machine | |
| WO2025204619A1 (en) | Work machine, system including work machine, and method for controlling work machine | |
| JP2024119548A (en) | SYSTEM INCLUDING WORK MACHINE, CONTROLLER FOR WORK MACHINE, AND ROUTE GENERATION METHOD FOR WORK MACHINE | |
| JP2026009536A (en) | Method, controller for a work machine, and system including a work machine | |
| JP2026070086A (en) | Control system for a work machine, method for controlling a work machine, and work machine | |
| JP2024126914A (en) | SYSTEM, CONTROLLER FOR WORK MACHINE, AND METHOD FOR DECIDING MATERIAL LOCATION - Patent application | |
| JP2024126915A (en) | SYSTEM INCLUDING WORK MACHINE, CONTROLLER FOR WORK MACHINE, AND ROUTE GENERATION METHOD FOR WORK MACHINE |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE INTERNATIONAL PUBLICATION HAS BEEN MADE |
|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20250123 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| DAV | Request for validation of the european patent (deleted) | ||
| DAX | Request for extension of the european patent (deleted) | ||
| A4 | Supplementary search report drawn up and despatched |
Effective date: 20260603 |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: E02F 3/43 20060101AFI20260528BHEP Ipc: E02F 9/20 20060101ALI20260528BHEP Ipc: E02F 9/08 20060101ALI20260528BHEP Ipc: E02F 9/26 20060101ALI20260528BHEP |