EP4007071B1 - Uniformly-partitioned high-precision sub-reflector device with two-stage pose adjustment function - Google Patents
Uniformly-partitioned high-precision sub-reflector device with two-stage pose adjustment function Download PDFInfo
- Publication number
- EP4007071B1 EP4007071B1 EP19939758.9A EP19939758A EP4007071B1 EP 4007071 B1 EP4007071 B1 EP 4007071B1 EP 19939758 A EP19939758 A EP 19939758A EP 4007071 B1 EP4007071 B1 EP 4007071B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- rod
- adjustment
- reflector
- uniformly
- sub
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images





Classifications
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01Q—ANTENNAS, i.e. RADIO AERIALS
- H01Q19/00—Combinations of primary active antenna elements and units with secondary devices, e.g. with quasi-optical devices, for giving the antenna a desired directional characteristic
- H01Q19/10—Combinations of primary active antenna elements and units with secondary devices, e.g. with quasi-optical devices, for giving the antenna a desired directional characteristic using reflecting surfaces
- H01Q19/18—Combinations of primary active antenna elements and units with secondary devices, e.g. with quasi-optical devices, for giving the antenna a desired directional characteristic using reflecting surfaces having two or more spaced reflecting surfaces
- H01Q19/19—Combinations of primary active antenna elements and units with secondary devices, e.g. with quasi-optical devices, for giving the antenna a desired directional characteristic using reflecting surfaces having two or more spaced reflecting surfaces comprising one main concave reflecting surface associated with an auxiliary reflecting surface
- H01Q19/192—Combinations of primary active antenna elements and units with secondary devices, e.g. with quasi-optical devices, for giving the antenna a desired directional characteristic using reflecting surfaces having two or more spaced reflecting surfaces comprising one main concave reflecting surface associated with an auxiliary reflecting surface with dual offset reflectors
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01Q—ANTENNAS, i.e. RADIO AERIALS
- H01Q15/00—Devices for reflection, refraction, diffraction or polarisation of waves radiated from an antenna, e.g. quasi-optical devices
- H01Q15/14—Reflecting surfaces; Equivalent structures
- H01Q15/147—Reflecting surfaces; Equivalent structures provided with means for controlling or monitoring the shape of the reflecting surface
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01Q—ANTENNAS, i.e. RADIO AERIALS
- H01Q15/00—Devices for reflection, refraction, diffraction or polarisation of waves radiated from an antenna, e.g. quasi-optical devices
- H01Q15/14—Reflecting surfaces; Equivalent structures
- H01Q15/16—Reflecting surfaces; Equivalent structures curved in two dimensions [2D], e.g. paraboloidal
- H01Q15/165—Reflecting surfaces; Equivalent structures curved in two dimensions [2D], e.g. paraboloidal composed of a plurality of rigid panels
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01Q—ANTENNAS, i.e. RADIO AERIALS
- H01Q3/00—Arrangements for changing or varying the orientation or the shape of the directional pattern of the waves radiated from an antenna or antenna system
- H01Q3/12—Arrangements for changing or varying the orientation or the shape of the directional pattern of the waves radiated from an antenna or antenna system using mechanical relative movement between primary active elements and secondary devices of antennas or antenna systems
- H01Q3/16—Arrangements for changing or varying the orientation or the shape of the directional pattern of the waves radiated from an antenna or antenna system using mechanical relative movement between primary active elements and secondary devices of antennas or antenna systems for varying relative position of primary active element and a reflecting device
- H01Q3/20—Arrangements for changing or varying the orientation or the shape of the directional pattern of the waves radiated from an antenna or antenna system using mechanical relative movement between primary active elements and secondary devices of antennas or antenna systems for varying relative position of primary active element and a reflecting device wherein the primary active element is fixed and the reflecting device is movable
Definitions
- the present invention relates to technical fields of communication, Telemetry, Track and Command (TT&C), and radio astronomy etc., and particularly to a uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function.
- T&C Telemetry, Track and Command
- radio astronomy etc. and particularly to a uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function.
- a dual-offset antenna has the characteristics that a main reflector is offset from a sub-reflector and the sub-reflector is offset from a feed.
- the dual-offset antenna overcomes not only an blockage of the sub-reflector to the main reflector, but also blockages of the feed and a supporting arm to the sub-reflector, thereby improving paraxial sidelobe characteristics of an antenna pattern and input voltage standing wave ratio characteristics of the feed, and achieving high antenna efficiency.
- Dual-offset Gregorian antenna has a compact structure with a large space between a primary feed and a sub-reflector, which can reduce a near-field effect and easily realize far-field conditions, and so is widely used.
- a feed-down offset antenna is employed in a lot of projects due to a low center of gravity and advantages for installation and maintenance of a receiving system.
- an international large scale scientific project - the Square Kilometre Array (SKA) radio telescope project adopts the feed-down dual-offset Gregorian reflector antenna.
- SKA Square Kilometre Array
- a geometric size of the sub-reflector and a relative positional relationship between the sub-reflector and the main reflector are both quite different from those of a circularly symmetric reflector antenna. How to precisely adjust the sub-reflector to a theoretical position is a key design problem. Otherwise, the position relationship between the main reflector and the sub-reflector will be incorrect, resulting in low antenna efficiency.
- the SKA project consists of 2,500 dual-offset reflector antennas with an aperture of 15 meters to receive weak radio signals from distant universe. Therefore, the antenna is required to have the characteristics of high efficiency, low noise, low cost and quick installation, wherein the antenna efficiency is required to be greater than 88% at 15GHz.
- a document ' DVA-C A Chinese Dish Prototype for the Square Kilometre Array' (2015 International Symposium on Antennas and Promotion ) introduces a development of a SKA prototype in China.
- a document ' The Design of the MeerKAT Dish Optics' (Electromagnetism in Advanced Applications, 2012 International Conference ) introduces a development of a SKA prototype in South Africa.
- a document ' Update on the SKA offset optics design for the U.S. Technology Development Project' (Aerospace, IEEE Conference, March 2011 ) introduces a development of a SKA prototype in Canada.
- the above three principle prototypes adopt an integral sub-reflector made of a composite material. Although this molding mode can simplify manufacturing procedures, the following defects are existed for the SKA project:
- a Chinese patent with a publication No. CN202712431U entitled 'Antenna Sub-Reflector System Comprising Fixed Adjusting Mechanism', discloses a device for adjusting a sub-reflector using a classical Stewart parallel mechanism.
- a Chinese patent with a publication No. CN105226370A entitled 'Antenna Structure System Based On 6/6-Upu Parallel Mechanism', discloses a device that uses a hexapod parallel mechanism as an antenna pedestal to realize a vertex tracking function.
- CN106450653A entitled 'Parallel Type Six-Freedom-Degree Redundant Driving Antenna Structural System', discloses a mechanism that realizes a negative angle in elevation for antenna by combining a hexapod parallel mechanism with a cone.
- a document ' Orientation of Radio-Telescope Secondary Mirror Via Parallel Platform' introduces a parallel mechanism with a six-degree-of-freedom adjustment for a sub-reflector.
- a document ' Stiffness Study of a Hexapod Telescope Platform' introduces a device using a hexapod mechanism as a pedestal of a planar antenna array.
- the above parallel mechanisms can realize a six-degree-of-freedom adjustment of an antenna or a sub-reflector, but for applications such as an adjustment of a sub-reflector of a dual-offset reflector antenna, the following defects are existed:
- a back of each panel needs to be provided with adjustment points.
- the traditional adjustment method of an antenna panel adopts several studs which are arranged on the back of the panel and then connected to an antenna backup structure. During adjustment, a movement of the antenna panel is realized by adjusting a screwing length of the studs.
- a Chinese patent with a publication No. CN202004142U entitled 'Positioning Connection Device of Combined Antenna Panel', discloses an antenna panel connection device using a combination of taper pins and screw nuts.
- a Chinese patent with a publication No. CN108172970A entitled ⁇ antenna panel assembling structure', discloses an antenna panel adjustment structure with a spherical hinge.
- a Chinese patent with a publication No. CN108155482A entitled ⁇ Structure of High-Precision Reflector Antenna Composite Panel and Adjustment Method thereof', discloses an adjustment method of a composite panel with a normal adjustment function.
- a document ' Design, construction, and performance of the Leighton 10.4-m-diameter radio telescopes' (Proceedings of the IEEE, May 1994 ) introduces a panel adjustment device with an aluminum honeycomb sandwich structure.
- a document ' Surface adjustment of the IRAM 30 m radio telescope' (Microwaves, Antennas & Propagation, IET, 2009 ) introduces an adjustment device with a truss structure panel.
- An objective of the present invention is to overcome the defects of the prior arts, and provides a uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function, which has the characteristics of high surface accuracy, high adjustment precision, high adjustment efficiency, high stiffness and light weight.
- the present invention has the following advantageous effects:
- the present invention is ingenious in conceptions, clear in ideas and easy to be realized, which not only solves the problems of the poor precision and the low efficiency of the traditional single-stage adjustment, but also improves the reliability and the design flexibility of the parallel mechanism, thereby achieving an important improvement of the prior arts.
- a dual-bias antenna is generally composed of a main reflector, a sub-reflector and a feed, wherein the sub-reflector is in the middle of an electromagnetic path between the main reflector and the feed for a secondary reflection of electromagnetic waves.
- the surface accuracy and position precision of the sub-reflector directly determine key specifications of the dual-offset antenna, such as efficiency, sidelobe and cross polarization.
- a sub-reflector adjustment device with an aperture of 5 meters in the dual-offset antenna is taken as an example.
- a sub-reflector device of the present invention comprises an adjustment device 1, a sub-reflector 2, a single-layer space frame backup structure 3 and a panel precise adjustment device 4.
- the adjustment device 1 is located in a direction of an aperture of the sub-reflector 2 and does not obstruct the sub-reflector 2, and comprises a movable platform 1-1, a fixed platform 1-2, a primary adjustment rod 1-3, an auxiliary adjustment rod 1-4, a movable platform spherical joint 1-5 and a fixed platform spherical joint 1-6.
- the movable platform 1-1 is connected to the single-layer space frame backup structure 3
- the fixed platform 1-2 is located outside the aperture of the sub-reflector 2, and an included angle between a plane where the movable platform 1-1 is located and a plane where the fixed platform 1-2 is located is 0° to 30°.
- an included angle ⁇ between a plane A where the movable platform 1-1 is located and a plane B where the fixed platform 1-2 is located is 15°.
- the fixed platform 1-2 is a plane truss structure with a N-polygonal shape, wherein N is a natural number and N ⁇ 4.
- the fixed platform 1-2 is composed of N fixed platform rods 1-2-1 to 1-2-N, every two of which are connected by the fixed platform spherical joint 1-6.
- the fixed platform 1-2 has a pentagonal shape, and is composed of a fixed platform rod 1-2-1, a fixed platform rod 1-2-2, a fixed platform rod 1-2-3, a fixed platform rod 1-2-4 and a fixed platform rod 1-2-5.
- the movable platform 1-1 is a plane truss structure with a 2N-polygonal shape, and is composed of 2N movable platform rods 1-1-1 to 1-1-2N, every two of which are connected by the movable platform spherical joint 1-5.
- the movable platform 1-1 has a decagonal shape, and is composed of a movable platform rod 1-1-1, a movable platform rod 1-1-2, a movable platform rod 1-1-3, a movable platform rod 1-1-4, a movable platform rod 1-1-5, a movable platform rod 1-1-6, a movable platform rod 1-1-7, a movable platform rod 1-1-8, a movable platform rod 1-1-9 and a movable platform rod 1-1-10.
- At least one of the N fixed platform spherical joints 1-6 is corresponding to the movable platform spherical joint 1-5.
- five joints of the fixed platform spherical joints 1-6 are corresponding to the movable platform spherical joints 1-5.
- the primary adjustment rod 1-3 is composed of N rod, with two ends connected to the movable platform spherical joint 1-5 and the fixed platform spherical joint 1-6, respectively, and the number of the primary adjustment rods 1-3 is N.
- the number of the primary adjustment rods 1-3 is 5.
- auxiliary adjustment rod 1-4 Two ends of the auxiliary adjustment rod 1-4 are connected to the movable platform spherical joint 1-5 and the fixed platform spherical joint 1-6, respectively, and the number of the auxiliary adjustment rods 1-4 is 2N.
- the number of the auxiliary adjustment rods 1-4 is 10.
- Each of the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 comprises spherical hinges located at the two ends thereof, and a threaded structure with an adjustable length located in the middle thereof.
- the movable platform rod 1-1, the fixed platform rod 1-2, the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 form a mesh structure with a plurality of triangular space regions.
- the adjustment device 1 is a mesh structure composed of 15 triangular space regions.
- the sub-reflector 2 is composed of an N-polygonal panel 2-1 and N sectorial panels 2-2, wherein the N sectorial panels 2-2 are radially distributed around the N-polygonal panel 2-1 and each has an area substantially equal to that of the N-polygonal panel 2-1, and the sub-reflector 2 is connected to the single-layer space frame backup structure 3 through the panel precise adjustment device 4.
- the sub-reflector 2 is composed of a pentagonal panel 2-1 and five sectorial panels 2-2, with an area of the pentagonal panel 2-1 being 3.7m 2 and an area of the sectorial panel 2-2 being 3.4m 2 .
- the single-layer space frame back frame 3 is composed of an inner ring support 3-1, a main rod 3-2, a diagonal rod 3-3 and an inner spherical joint 3-4.
- the inner ring support 3-1 and the movable platform 1-1 are respectively located in two planes with a distance of 500 mm to 3000 mm therebetween.
- the distance between the two planes is 1000 mm.
- the inner ring support 3-1 has an N-polygonal shape, and is composed of N inner ring rods 3-1-1 to 3-1-N, every two of which are connected to each other through the inner ring spherical joint 3-4.
- the inner ring support 3-1 has a pentagonal shape, and is composed of an inner ring rod 3-1-1, an inner ring rod 3-1-2, an inner ring rod 3-1-3, an inner ring rod 3-1-4 and an inner ring rod 3-1-5.
- At least one of the N inner ring spherical joints 3-4 is corresponding to the movable platform spherical joint 1-5.
- the five inner ring spherical joints 3-4 are all corresponding to the movable platform spherical joints 1-5.
- Two ends of the main rod 3-2 are connected to the inner ring spherical joint 3-4 and the movable platform spherical joint 1-5, respectively, and the number of the main rods 3-2 is N.
- the number of the main rods 3-2 is 5.
- Two ends of the diagonal rod 3-3 are connected to the inner ring spherical joint 3-4 and the movable platform spherical joints 1-5, respectively, and the number of the diagonal rods 3-3 is 2N.
- the number of the diagonal rods 3-3 is 10.
- the inner ring rod 3-1-1, the movable platform rod 1-1-1 to 1-1-2n, the main rod 3-2 and the diagonal rod 3-3 form a mesh structure with a plurality of triangular space regions.
- the single-layer space frame backup structure 3 is a mesh structure composed of 15 triangular space regions.
- the panel precise adjustment device 4 comprises a positioning mechanism 4-1 and an adjustment mechanism 4-2.
- the positioning mechanism 4-1 is located at connection points between the N-polygonal panel 2-1 and the inner ring spherical joint 3-4 of the single-layer space frame backup structure 3, and connection points between the N sectorial panels 2-2 and the inner ring spherical joint 3-4 of the single-layer space frame backup structure 3.
- the number of the positioning mechanisms 4-1 is 10.
- the positioning mechanism 4-1 is composed of a main supporting rod 4-1-1, an independent supporting rod 4-1-2, a first direction connection plate 4-1-3, a second direction connection plate 4-1-4, a screw nut 4-1-5, a spherical washer 4-1-6, and a conical washer 4-1-7.
- An axial direction of the main supporting rod 4-1-1 is the same as a normal direction of the panel at the position of the main supporting rod 4-1-1.
- the first direction connection plate 4-1-3 is connected to the single-layer space frame backup structure 3 through the main supporting rod 4-1-1.
- the second direction connection plate 4-1-4 is connected to the panel through a fastener or glue.
- the first direction connection plate 4-1-3 and the second direction connection plate 4-1-4 are provided with oblong holes having extending directions orthogonal to each other.
- the independent supporting rod 4-1-2 is located between the first direction connection plate 4-1-3 and the second direction connection plate 4-1-4, with an upper end thereof located in the oblong hole of the second direction connection plate 4-1-4 and fixed by the screw nut 4-1-5, and a lower end thereof located in the oblong hole of the first direction connection plate 4-1-3 and fixed by the nut 4-1-5, the spherical washer 4-1-6, and the conical washer 4-1-7.
- the adjustment mechanism 4-2 is located at a non-working side of the antenna panel and composed of a V-shaped rod 4-2-1, a unidirectional rod 4-2-2, a dual-joint support 4-2-3 and a single-joint support 4-2-4.
- the V-shaped rod 4-2-1 comprises an A-link 4-2-1-1 and a B-link 4-2-1-2 with adjustable lengths and each having spherical hinges at two ends.
- One end of each of the A-link 4-2-1-1 and the B-link 4-2-1-2 is connected to the single-layer space frame backup structure 3, and the other end thereof is connected to the dual-joint support 4-2-3.
- the unidirectional rod 4-2-2 has an adjustable length and provided with spherical hinges at two ends thereof, wherein one end is connected to the single-layer space frame backup structure 3, and the other end is connected to the single-joint support 4-2-4.
- a ratio of a maximum curved surface area to a minimum curved surface area among the N-polygonal panel 2-1 and the N sectorial panels 2-2 is 1 to 1.3.
- the ratio of the maximum curved surface area to the minimum curved surface area among the pentagonal panel 2-1 and five sectorial panels 2-2 is 1.1.
- an intermediate threaded structure of the main adjustment rod 1-3 and the auxiliary adjustment rod 1-4 has an adjustable length and has left-handed and right-handed threads in combination.
- the spherical hinges at the two ends of each of the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 are ball bearings.
- the inner ring rods 3-1-1 to 3-1-5, the movable platform rods 1-1-1 to 1-1-10, the main rod 3-2 and the diagonal rod 3-3 each comprises a circular tube, a conical head, a high-strength bolt and a screw nut.
- An intermediate threaded structure of the A-link 4-2-1-1, the B-link 4-2-1-2 and the unidirectional rod 4-2-2 has an adjustable length and has left-handed and right-handed threads in combination.
- the screw nut 4-1-5, the spherical washers 4-1-6 and the conical washers 4-1-7 are symmetrically distributed on two sides of the first direction connection plate 4-1-3.
- the dual-joint support 4-2-3 is located at a center of gravity of the antenna panel and connected thereto through a fastener or glue.
- the single-joint support 4-2-4 is located under the antenna panel and connected thereto through a fastener or glue.
- a gap between the N-polygonal panel 2-1 and the N sectorial panels 2-2 constituting the sub-reflector 2 is 0.2 to 5 mm.
- the gap between the pentagonal panel 2-1 and five sectorial panels 2-2 is 2 mm.
- the adjustment principle of the sub-reflector device of the present invention is as follows:
- the sub-reflector device of the present invention comprises an adjustment device, a sub-reflector, a single-layer space frame backup structure and a panel precise adjustment device.
- the adjustment device adopts movable and fixed platforms as a multi-rod six-degree-of-freedom sub-reflector adjustment mechanism for a plane truss to realize a primary pose adjustment of the sub-reflector.
- the sub-reflector is composed of a polygonal panel and several sectorial panels, and an area of each sectorial panel is substantially equal to that of the polygonal panel.
- the numbers of inner and outer sides of the single-layer space frame backup structure is in a ratio of 1: 2, which provides a support stiffness for the sub-reflector.
- the panel precise adjustment device comprises a positioning mechanism for adjusting the panel in a normal direction and an adjustment mechanism for adjusting a movement of the sub-reflector.
- a sub-reflector device not only realizes a two-stage position and pose adjustment of the sub-reflector, but also improves the integral stiffness and reduces the overall weight of the sub-reflector system, while improving the installation and adjustment efficiency and reducing the manufacturing cost.
Landscapes
- Physics & Mathematics (AREA)
- Electromagnetism (AREA)
- Aerials With Secondary Devices (AREA)
- Variable-Direction Aerials And Aerial Arrays (AREA)
Description
- The present invention relates to technical fields of communication, Telemetry, Track and Command (TT&C), and radio astronomy etc., and particularly to a uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function.
- A dual-offset antenna has the characteristics that a main reflector is offset from a sub-reflector and the sub-reflector is offset from a feed. The dual-offset antenna overcomes not only an blockage of the sub-reflector to the main reflector, but also blockages of the feed and a supporting arm to the sub-reflector, thereby improving paraxial sidelobe characteristics of an antenna pattern and input voltage standing wave ratio characteristics of the feed, and achieving high antenna efficiency.
- Dual-offset Gregorian antenna has a compact structure with a large space between a primary feed and a sub-reflector, which can reduce a near-field effect and easily realize far-field conditions, and so is widely used. A feed-down offset antenna is employed in a lot of projects due to a low center of gravity and advantages for installation and maintenance of a receiving system.
- Just because of the above advantages of the dual-offset antenna, an international large scale scientific project - the Square Kilometre Array (SKA) radio telescope project adopts the feed-down dual-offset Gregorian reflector antenna.
- In the dual-offset antenna, a geometric size of the sub-reflector and a relative positional relationship between the sub-reflector and the main reflector are both quite different from those of a circularly symmetric reflector antenna. How to precisely adjust the sub-reflector to a theoretical position is a key design problem. Otherwise, the position relationship between the main reflector and the sub-reflector will be incorrect, resulting in low antenna efficiency.
- The SKA project consists of 2,500 dual-offset reflector antennas with an aperture of 15 meters to receive weak radio signals from distant universe. Therefore, the antenna is required to have the characteristics of high efficiency, low noise, low cost and quick installation, wherein the antenna efficiency is required to be greater than 88% at 15GHz.
- At present, the SKA project has completed three pathfinder antennas. A document 'DVA-C: A Chinese Dish Prototype for the Square Kilometre Array' (2015 International Symposium on Antennas and Promotion) introduces a development of a SKA prototype in China. A document 'The Design of the MeerKAT Dish Optics' (Electromagnetism in Advanced Applications, 2012 International Conference) introduces a development of a SKA prototype in South Africa. A document 'Update on the SKA offset optics design for the U.S. Technology Development Project' (Aerospace, IEEE Conference, March 2011) introduces a development of a SKA prototype in Canada. The above three principle prototypes adopt an integral sub-reflector made of a composite material. Although this molding mode can simplify manufacturing procedures, the following defects are existed for the SKA project:
- (1) A mold required by the integral sub-reflector is also of an integral structure with a large geometric size, which leads to a low processing precision. In a molding procedure of a large-size composite material, it is easy to cause defects of internal stress and uneven shrinkage, which leads to a decrease of an overall precision of the molded sub-reflector.
- (2) The above three integral sub-reflectors are not provided with precision adjustment points, and the precision of the molded sub-reflector cannot be controlled, which reduces the yield.
- (3) The above three types of sub-reflector have few structural supporting points, and when the antenna travels in elevation, it is easy to cause a deformation and affect the efficiency of the antenna.
- With the improvement of computing power, a parallel mechanism has been applied to the adjustment of sub-reflectors of a plurality of reflector antennas. A Chinese patent with a publication No.
CN202712431U , entitled 'Antenna Sub-Reflector System Comprising Fixed Adjusting Mechanism', discloses a device for adjusting a sub-reflector using a classical Stewart parallel mechanism. A Chinese patent with a publication No.CN105226370A , entitled 'Antenna Structure System Based On 6/6-Upu Parallel Mechanism', discloses a device that uses a hexapod parallel mechanism as an antenna pedestal to realize a vertex tracking function. A Chinese patent with a publication No.CN106450653A , entitled 'Parallel Type Six-Freedom-Degree Redundant Driving Antenna Structural System', discloses a mechanism that realizes a negative angle in elevation for antenna by combining a hexapod parallel mechanism with a cone. A document 'Orientation of Radio-Telescope Secondary Mirror Via Parallel Platform' (Electrical Engineering, Computing Science and Automatic Control, 2015 12th International Conference) introduces a parallel mechanism with a six-degree-of-freedom adjustment for a sub-reflector. A document 'Stiffness Study of a Hexapod Telescope Platform' (Antennas and Propagation, IEEE Transactions, 2011) introduces a device using a hexapod mechanism as a pedestal of a planar antenna array. The above parallel mechanisms can realize a six-degree-of-freedom adjustment of an antenna or a sub-reflector, but for applications such as an adjustment of a sub-reflector of a dual-offset reflector antenna, the following defects are existed: - (1) The local stiffness is low. The traditional parallel mechanism generally consists of six driving rods, a movable platform and a fixed platform, and the movable platform is connected to the driving rods through three supporting points. When an aperture of a sub-reflector is large, the movable platform, which serves as an installation foundation of the sub-reflector, may cause a low stiffness at a connection position due to too few supporting points, thereby reducing the surface accuracy of the sub-reflector.
- (2) The designability is poor. In order to meet the demand of space solution, the position distribution of rod cannot be arbitrarily configured in the traditional parallel mechanism. Particularly, in the dual-offset antenna, when the fixed platform is required to be located outside the aperture of the sub-reflector, great difficulties will be brought to the structural design.
- (3) There is no redundant design. The hexapod parallel mechanism adopts six driving systems. When one driver or rod fails, the system cannot work normally, and even the device safety will be affected.
- For a reflector of a partitioned antenna, a back of each panel needs to be provided with adjustment points. The traditional adjustment method of an antenna panel adopts several studs which are arranged on the back of the panel and then connected to an antenna backup structure. During adjustment, a movement of the antenna panel is realized by adjusting a screwing length of the studs. A Chinese patent with a publication No.
CN202004142U , entitled 'Positioning Connection Device of Combined Antenna Panel', discloses an antenna panel connection device using a combination of taper pins and screw nuts. A Chinese patent with a publication No.CN108172970A , entitled `antenna panel assembling structure', discloses an antenna panel adjustment structure with a spherical hinge. A Chinese patent with a publication No.CN108155482A , entitled `Structure of High-Precision Reflector Antenna Composite Panel and Adjustment Method thereof', discloses an adjustment method of a composite panel with a normal adjustment function. A document 'Design, construction, and performance of the Leighton 10.4-m-diameter radio telescopes' (Proceedings of the IEEE, May 1994) introduces a panel adjustment device with an aluminum honeycomb sandwich structure. A document 'Surface adjustment of the IRAM 30 m radio telescope' (Microwaves, Antennas & Propagation, IET, 2009) introduces an adjustment device with a truss structure panel. Although the above partitioned panel adjustment structures can meet the requirement of a reflector antenna with a certain precision or a circularly symmetric reflector antenna, the following defects are existed for a sub-reflector of a dual-offset reflector antenna requiring high position precision and high surface accuracy: - (1) An adjustment method of a planar movement of the panel is not mentioned. The above adjustment devices can realize an axial continuous adjustment of the panel by means of threads, but there is no corresponding continuous adjustment mode for movement and adjustment in a horizontal plane of the panel.
- (2) The antenna panel needs to overcome the gravity adjustment in different poses, and the operation is difficult. As well known, the reflector antenna is in the form of a paraboloid, and a single panel has different poses when the position of the reflector is varied. For example, the signal panel has a small slope when being close to a central position of the reflector, while has a large slope when being at an edge of the reflector. When a panel with a very large slope is to be moved and adjusted, a counterweight thereof should be overcome, and a slip can easily occur during the adjustment. Particularly, great difficulties and even dangers will be brought to the operators working at a high altitude.
- (3) The adjustment efficiency is low, and it is easy to cause the adjustment position not to converge. In case of a device without a continuous movement or adjustment, it depends entirely on artificial experiences, and when a direction is to be adjusted, other adjusted directions will be affected, resulting in a vicious circle that the adjustment position of the panel does not converge.
- An objective of the present invention is to overcome the defects of the prior arts, and provides a uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function, which has the characteristics of high surface accuracy, high adjustment precision, high adjustment efficiency, high stiffness and light weight.
- In order to achieve the above objective, the present invention adopts the following technical solutions:
- A uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function, comprising an adjustment device 1, a
sub-reflector 2, a single-layer spaceframe backup structure 3 and a panel precise adjustment device 4; - wherein the adjustment device 1 is located in a direction of an aperture of the sub-reflector 2 and comprises a movable platform 1-1, a fixed platform 1-2, a primary adjustment rod 1-3, an auxiliary adjustment rod 1-4, a movable platform spherical joint 1-5 and a fixed platform spherical joint 1-6; the movable platform 1-1 is connected to the single-layer space frame backup structure 3, and the fixed platform 1-2 is located outside the aperture of the sub-reflector 2; the fixed platform 1-2 is a plane truss structure with an N-polygonal shape, wherein N is a natural number and N≥4; the fixed platform 1-2 is composed of N fixed platform rods 1-2-1 to 1-2-N, every two of which are connected by the fixed platform spherical joint 1-6; the movable platform 1-1 is a plane truss structure with a 2N-polygonal shape, and is composed of 2N movable platform rods 1-1-1 to 1-1-2N, every two of which are connected by the movable platform spherical joint 1-5; the movable platform rod 1-1-1 to 1-1-2N, the fixed platform rod 1-2-1 to 1-2-N, the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 form a mesh structure with a plurality of triangular space regions;
- the
sub-reflector 2 is composed of an N-polygonal panel 2-1 and N sectorial panels 2-2, with the N sectorial panels 2-2 being radially distributed around the N-polygonal panel 2-1 and each having an area substantially equal to that of the N-polygonal panel 2-1, and the sub-reflector 2 being connected to the single-layer spaceframe backup structure 3 through the panel precise adjustment device 4; - the single-layer space
frame backup structure 3 is composed of an inner ring support 3-1, a main rod 3-2, a diagonal rod 3-3 and an inner ring spherical joint 3-4; wherein the inner ring support 3-1 has an N-polygonal shape and is composed of N inner ring rods 3-1-1 to 3-1-N, every two of which are connected to each other through the inner ring spherical joint 3-4; the inner ring rod 3-1-1, the movable platform rod 1-1-1 to 1-1-2N, the main rod 3-2 and the diagonal rod 3-3 form a mesh structure with a plurality of triangular space regions; - the panel precise adjustment device 4 comprises a positioning mechanism 4-1 and an adjustment mechanism (4-2), with the positioning mechanism (4-1) being located at connection points between the N-polygonal panel 2-1 and the inner ring spherical joint 3-4 of the single-layer space
frame backup structure 3, and connection points between the N sectorial panels 2-2 and the inner ring spherical joint 3-4 of the single-layer spaceframe backup structure 3; and the adjustment mechanism 4-2 being located at a non-working side of an antenna panel. - Compared with the background art, the present invention has the following advantageous effects:
- (1) Compared with the prior arts, the two-stage adjustment device adopted by the present invention has the characteristics of high adjustment precision and high adjustment efficiency. The adjustment device is a multi-rod parallel mechanism which can realize a primary six-degree-of-freedom pose adjustment of the sub-reflector; and the panel precise adjustment device can realize a surface accuracy adjustment and a secondary pose adjustment of the sub-reflector.
- (2) Each of the adjustment device and the single-layer space frame backup structure in the present invention is composed of a plurality of triangular units, thereby having a stable mechanical performance, effectively resisting a gravity deformation of the antenna during the elevation travelling, improving the dynamic performance of the antenna system, and achieving the advantages of high stiffness and light weight.
- (3) The parallel mechanism adopted by the adjustment device of the present invention is of a redundant design, and the number of adjustment rod is more than that of the traditional hexapod structure. When some rods fail or invalid, the adjustment device can still work normally, and the structure is stable without affecting the antenna system, which achieves the characteristics of high reliability.
- (4) In the partitioning method adopted by the sub-reflector of the present invention, the reflector is composed of a polygon, and several sectorial units which are positioned through outer edges of the polygon, thereby overcoming the defect that the sectorial units are difficult to be positioned in the circumferential direction in the traditional method.
- (5) The panel precise adjustment device of the present invention adds a lateral connection for the panel and improves the dynamic performance of the antenna. The adjustment mechanism not only provides a continuous adjustment in the plane direction, but also provides a lateral support for the antenna panel in two directions. When the antenna is in an elevation motion, this lateral support can reduce the movement of the panel, thereby improving the overall precision and the dynamic performance of the antenna system.
- (6) The present invention provides an equation for calculating an adjustment amount of the panel precise adjustment device of the sub-reflector, and the corresponding adjustment amount can be calculated according to this equation, thereby providing a data basis for the precise adjustment of the panel.
- (7) In the present invention, the movable platform and the fixed platform which constitute the adjustment device adopt a hollow plane truss structure, which is located outside the aperture of the sub-reflector to form an unobstructed electromagnetic channel.
- (8) The adjustment device of the present invention is easy for operation, which improves the adjusting efficiency of the panel. Regardless of the posture of the antenna panel, an operator can realize the adjustments of rotation and movement of the panel by rotating corresponding rod, thereby overcoming the disadvantages of the traditional adjustment that manually pushes the panel, and achieving the characteristics of high adjustment efficiency and safe operation.
- To sum up, the present invention is ingenious in conceptions, clear in ideas and easy to be realized, which not only solves the problems of the poor precision and the low efficiency of the traditional single-stage adjustment, but also improves the reliability and the design flexibility of the parallel mechanism, thereby achieving an important improvement of the prior arts.
-
-
Fig. 1 is a schematic diagram of a system composition according to an embodiment of the present invention; -
Fig. 2 is a schematic diagram of an overall structure composition according to an embodiment of the present invention; -
Fig. 3 is a schematic diagram of a structure composition of an adjustment device according to an embodiment of the present invention; -
Fig. 4 is a schematic diagram of partitioning of a sub-reflector according to an embodiment of the present invention; -
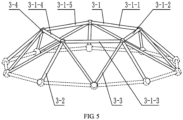
Fig. 5 is a schematic diagram of a structure composition of a single-layer space frame backup structure according to an embodiment of the present invention; -
Fig. 6 is a schematic diagram of an overall distribution of a panel precise adjustment device according to an embodiment of the present invention; -
Fig. 7 is a schematic diagram of a structure composition of a panel precise adjustment device according to an embodiment of the present invention; -
Fig. 8 is a schematic diagram of a structure composition of a positioning mechanism according to an embodiment of the present invention; -
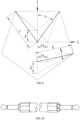
Fig. 9 is a schematic diagram of calculation parameters of an adjustment mechanism according to an embodiment of the present invention; -
Fig. 10 is a structural diagram of a link of an adjustment mechanism according to an embodiment of the present invention; -
Fig. 11 is a structural diagram of a joint of a single-layer space frame backup structure according to an embodiment of the present invention; -
Fig. 12 is a gravity deformation diagram of an antenna panel in an x-direction in the background art; -
Fig. 13 is a gravity deformation diagram of an antenna panel in a Y direction in the background art; -
Fig. 14 is a gravity deformation diagram of an antenna panel in an x-direction in the present invention; -
Fig. 15 is a gravity deformation diagram of an antenna panel in a Y direction in the present invention; -
Fig. 16 is a deformation diagram of a sub-reflector in a vertical state according to an embodiment of the present invention; -
Fig. 17 is a deformation diagram of a sub-reflector in a horizontal state according to an embodiment of the present invention; -
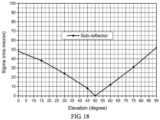
Fig. 18 is a surface accuracy curve of a sub-reflector at different elevation angles according to an embodiment of the present invention. -
- adjustment device 1, movable platform 1-1, movable platform rod 1-1-1, movable platform rod 1-1-2, movable platform rod 1-1-3, movable platform rod 1-1-4, movable platform rod 1-1-5, movable platform rod 1-1-6, movable platform rod 1-1-7, movable platform rod 1-1-8, movable platform rod 1-1-9, movable platform rod 1-1-10, fixed platform 1-2, fixed platform rod 1-2-1, fixed platform rod 1-2-2, fixed platform rod 1-2-3, fixed platform rod 1-2-4, fixed platform rod 1-2-5, main adjustment rod 1-3, auxiliary adjustment rod 1-4, movable platform spherical joint 1-5, fixed platform spherical joint 1-6;
- sub-reflector 2, pentagonal panel 2-1, sectorial panel 2-2;
- single-layer space
frame backup structure 3, inner ring support 3-1, inner ring rod 3-1-1, inner ring rod 3-1-2, inner ring rod 3-1-3, inner ring rod 3-1-4, inner ring rod 3-1-5, main rod 3-2, diagonal rod 3-3, inner ring spherical joint 3-4; - panel precise adjustment device 4, positioning mechanism 4-1, main supporting rod 4-1-1, independent supporting rod 4-1-2, first direction connection plate 4-1-3, second direction connection plate 4-1-4, screw nut 4-1-5, spherical washer 4-1-6, conical washer 4-1-7, adjustment mechanism 4-2, V-shaped rod 4-2-1, A-link 4-2-1-1, B-link 4-2-1-2, unidirectional rod 4-2-2, dual joint support 4-2-3, single joint support 4-2-4.
- The present invention will be further described below with reference to the drawings and specific embodiments.
- As illustrated in
Fig. 1 , a dual-bias antenna is generally composed of a main reflector, a sub-reflector and a feed, wherein the sub-reflector is in the middle of an electromagnetic path between the main reflector and the feed for a secondary reflection of electromagnetic waves. The surface accuracy and position precision of the sub-reflector directly determine key specifications of the dual-offset antenna, such as efficiency, sidelobe and cross polarization. - In this embodiment, a sub-reflector adjustment device with an aperture of 5 meters in the dual-offset antenna is taken as an example. As illustrated in
Fig. 2 , a sub-reflector device of the present invention comprises an adjustment device 1, asub-reflector 2, a single-layer spaceframe backup structure 3 and a panel precise adjustment device 4. - As illustrated in
Fig. 3 , the adjustment device 1 is located in a direction of an aperture of thesub-reflector 2 and does not obstruct thesub-reflector 2, and comprises a movable platform 1-1, a fixed platform 1-2, a primary adjustment rod 1-3, an auxiliary adjustment rod 1-4, a movable platform spherical joint 1-5 and a fixed platform spherical joint 1-6. The movable platform 1-1 is connected to the single-layer spaceframe backup structure 3, the fixed platform 1-2 is located outside the aperture of the sub-reflector 2, and an included angle between a plane where the movable platform 1-1 is located and a plane where the fixed platform 1-2 is located is 0° to 30°. - In this example, an included angle α between a plane A where the movable platform 1-1 is located and a plane B where the fixed platform 1-2 is located is 15°.
- The fixed platform 1-2 is a plane truss structure with a N-polygonal shape, wherein N is a natural number and N≥4. The fixed platform 1-2 is composed of N fixed platform rods 1-2-1 to 1-2-N, every two of which are connected by the fixed platform spherical joint 1-6.
- In this example, the fixed platform 1-2 has a pentagonal shape, and is composed of a fixed platform rod 1-2-1, a fixed platform rod 1-2-2, a fixed platform rod 1-2-3, a fixed platform rod 1-2-4 and a fixed platform rod 1-2-5.
- The movable platform 1-1 is a plane truss structure with a 2N-polygonal shape, and is composed of 2N movable platform rods 1-1-1 to 1-1-2N, every two of which are connected by the movable platform spherical joint 1-5.
- In this example, the movable platform 1-1 has a decagonal shape, and is composed of a movable platform rod 1-1-1, a movable platform rod 1-1-2, a movable platform rod 1-1-3, a movable platform rod 1-1-4, a movable platform rod 1-1-5, a movable platform rod 1-1-6, a movable platform rod 1-1-7, a movable platform rod 1-1-8, a movable platform rod 1-1-9 and a movable platform rod 1-1-10.
- At least one of the N fixed platform spherical joints 1-6 is corresponding to the movable platform spherical joint 1-5.
- In this example, five joints of the fixed platform spherical joints 1-6 are corresponding to the movable platform spherical joints 1-5.
- The primary adjustment rod 1-3 is composed of N rod, with two ends connected to the movable platform spherical joint 1-5 and the fixed platform spherical joint 1-6, respectively, and the number of the primary adjustment rods 1-3 is N.
- In this example, the number of the primary adjustment rods 1-3 is 5.
- Two ends of the auxiliary adjustment rod 1-4 are connected to the movable platform spherical joint 1-5 and the fixed platform spherical joint 1-6, respectively, and the number of the auxiliary adjustment rods 1-4 is 2N.
- In this example, the number of the auxiliary adjustment rods 1-4 is 10.
- Each of the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 comprises spherical hinges located at the two ends thereof, and a threaded structure with an adjustable length located in the middle thereof. The movable platform rod 1-1, the fixed platform rod 1-2, the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 form a mesh structure with a plurality of triangular space regions.
- In this example, the adjustment device 1 is a mesh structure composed of 15 triangular space regions.
- As illustrated in
Fig. 4 , thesub-reflector 2 is composed of an N-polygonal panel 2-1 and N sectorial panels 2-2, wherein the N sectorial panels 2-2 are radially distributed around the N-polygonal panel 2-1 and each has an area substantially equal to that of the N-polygonal panel 2-1, and thesub-reflector 2 is connected to the single-layer spaceframe backup structure 3 through the panel precise adjustment device 4. - In this example, the
sub-reflector 2 is composed of a pentagonal panel 2-1 and five sectorial panels 2-2, with an area of the pentagonal panel 2-1 being 3.7m2 and an area of the sectorial panel 2-2 being 3.4m2. - As illustrated in
Fig. 5 , the single-layer space frame backframe 3 is composed of an inner ring support 3-1, a main rod 3-2, a diagonal rod 3-3 and an inner spherical joint 3-4. - The inner ring support 3-1 and the movable platform 1-1 are respectively located in two planes with a distance of 500 mm to 3000 mm therebetween.
- In this example, the distance between the two planes is 1000 mm.
- The inner ring support 3-1 has an N-polygonal shape, and is composed of N inner ring rods 3-1-1 to 3-1-N, every two of which are connected to each other through the inner ring spherical joint 3-4.
- In this example, the inner ring support 3-1 has a pentagonal shape, and is composed of an inner ring rod 3-1-1, an inner ring rod 3-1-2, an inner ring rod 3-1-3, an inner ring rod 3-1-4 and an inner ring rod 3-1-5.
- At least one of the N inner ring spherical joints 3-4 is corresponding to the movable platform spherical joint 1-5.
- In this example, the five inner ring spherical joints 3-4 are all corresponding to the movable platform spherical joints 1-5.
- Two ends of the main rod 3-2 are connected to the inner ring spherical joint 3-4 and the movable platform spherical joint 1-5, respectively, and the number of the main rods 3-2 is N.
- In this example, the number of the main rods 3-2 is 5.
- Two ends of the diagonal rod 3-3 are connected to the inner ring spherical joint 3-4 and the movable platform spherical joints 1-5, respectively, and the number of the diagonal rods 3-3 is 2N.
- In this example, the number of the diagonal rods 3-3 is 10.
- The inner ring rod 3-1-1, the movable platform rod 1-1-1 to 1-1-2n, the main rod 3-2 and the diagonal rod 3-3 form a mesh structure with a plurality of triangular space regions.
- In this example, the single-layer space
frame backup structure 3 is a mesh structure composed of 15 triangular space regions. - As illustrated in
Fig. 6 , the panel precise adjustment device 4 comprises a positioning mechanism 4-1 and an adjustment mechanism 4-2. The positioning mechanism 4-1 is located at connection points between the N-polygonal panel 2-1 and the inner ring spherical joint 3-4 of the single-layer spaceframe backup structure 3, and connection points between the N sectorial panels 2-2 and the inner ring spherical joint 3-4 of the single-layer spaceframe backup structure 3. - In this example, the number of the positioning mechanisms 4-1 is 10.
- As illustrated in
Figs. 7 and8 , the positioning mechanism 4-1 is composed of a main supporting rod 4-1-1, an independent supporting rod 4-1-2, a first direction connection plate 4-1-3, a second direction connection plate 4-1-4, a screw nut 4-1-5, a spherical washer 4-1-6, and a conical washer 4-1-7. An axial direction of the main supporting rod 4-1-1 is the same as a normal direction of the panel at the position of the main supporting rod 4-1-1. The first direction connection plate 4-1-3 is connected to the single-layer spaceframe backup structure 3 through the main supporting rod 4-1-1. The second direction connection plate 4-1-4 is connected to the panel through a fastener or glue. The first direction connection plate 4-1-3 and the second direction connection plate 4-1-4 are provided with oblong holes having extending directions orthogonal to each other. The independent supporting rod 4-1-2 is located between the first direction connection plate 4-1-3 and the second direction connection plate 4-1-4, with an upper end thereof located in the oblong hole of the second direction connection plate 4-1-4 and fixed by the screw nut 4-1-5, and a lower end thereof located in the oblong hole of the first direction connection plate 4-1-3 and fixed by the nut 4-1-5, the spherical washer 4-1-6, and the conical washer 4-1-7. - As illustrated in
Fig. 7 , the adjustment mechanism 4-2 is located at a non-working side of the antenna panel and composed of a V-shaped rod 4-2-1, a unidirectional rod 4-2-2, a dual-joint support 4-2-3 and a single-joint support 4-2-4. The V-shaped rod 4-2-1 comprises an A-link 4-2-1-1 and a B-link 4-2-1-2 with adjustable lengths and each having spherical hinges at two ends. One end of each of the A-link 4-2-1-1 and the B-link 4-2-1-2 is connected to the single-layer spaceframe backup structure 3, and the other end thereof is connected to the dual-joint support 4-2-3. The unidirectional rod 4-2-2 has an adjustable length and provided with spherical hinges at two ends thereof, wherein one end is connected to the single-layer spaceframe backup structure 3, and the other end is connected to the single-joint support 4-2-4. - As illustrated in
Fig. 9 , an adjustment amount of the panel by the adjustment mechanism 4-2 may be calculated in the following equations:

- wherein ΔLAx is an adjustment amount of the A-link in an x direction, ΔLBx is an adjustment amount of the B-link in the x direction, L is an initial length of the A-link and the B-link, α is a half angle between the A-link and the B-link, and Δx is an adjustment amount of the given panel in the x-direction;

- wherein ΔLy is an adjustment amount of the A-link and the B-link in a y-direction; and Δy is an adjustment amount of the given panel in the y-direction;


- wherein ΔRx is an adjustment amount of the unidirectional rod in the x-direction, ΔRy is an adjustment amount of the unidirectional rod in the y-direction, R is an initial length of the unidirectional rod, β is an included angle between the unidirectional rod and a horizontal axis, Δx is an adjustment amount of the given panel in the x-direction, and Δy is an adjustment amount of the given panel in the y-direction.
- A ratio of a maximum curved surface area to a minimum curved surface area among the N-polygonal panel 2-1 and the N sectorial panels 2-2 is 1 to 1.3.
- In this example, the ratio of the maximum curved surface area to the minimum curved surface area among the pentagonal panel 2-1 and five sectorial panels 2-2 is 1.1.
- As illustrated in
Fig. 10 , an intermediate threaded structure of the main adjustment rod 1-3 and the auxiliary adjustment rod 1-4 has an adjustable length and has left-handed and right-handed threads in combination. The spherical hinges at the two ends of each of the primary adjustment rod 1-3 and the auxiliary adjustment rod 1-4 are ball bearings. - As illustrated in
Fig. 11 , the inner ring rods 3-1-1 to 3-1-5, the movable platform rods 1-1-1 to 1-1-10, the main rod 3-2 and the diagonal rod 3-3 each comprises a circular tube, a conical head, a high-strength bolt and a screw nut. - An intermediate threaded structure of the A-link 4-2-1-1, the B-link 4-2-1-2 and the unidirectional rod 4-2-2 has an adjustable length and has left-handed and right-handed threads in combination.
- The screw nut 4-1-5, the spherical washers 4-1-6 and the conical washers 4-1-7 are symmetrically distributed on two sides of the first direction connection plate 4-1-3.
- The dual-joint support 4-2-3 is located at a center of gravity of the antenna panel and connected thereto through a fastener or glue. The single-joint support 4-2-4 is located under the antenna panel and connected thereto through a fastener or glue.
- A gap between the N-polygonal panel 2-1 and the N sectorial panels 2-2 constituting the
sub-reflector 2 is 0.2 to 5 mm. - In this example, the gap between the pentagonal panel 2-1 and five sectorial panels 2-2 is 2 mm.
- The adjustment principle of the sub-reflector device of the present invention is as follows:
- (1) Primary adjustment. Firstly, measuring the main reflector to determine adjustment information of the sub-reflector, which mainly includes displacement adjustment amount and rotation adjustment amount; performing a gradation process on the adjustment information of the sub-reflector to obtain primary adjustment values of the displacement adjustment amount and the rotation adjustment amount; rotating the primary adjustment rod and the auxiliary adjustment rod to adjust the displacement amount and the rotation amount of the sub-reflector , until reaching the primary adjustment values of the displacement adjustment amount and the rotation adjustment amount.
- (2) Secondary adjustment. Determining secondary adjustment information based on residuals after the primary adjustment; adjusting the positioning mechanism and the adjustment mechanism of the central N-polygonal panel to meet the requirement of the secondary adjustment amount; and adjusting the positioning mechanisms and the adjustment mechanisms of N peripheral sectorial panels respectively, to make the whole sub-reflector meet the requirement of the surface accuracy specification.
- The advantages of the panel precise adjustment device adopted in the present invention can be further illustrated by the following simulation analysis.
- (1) Model illustration. In order to illustrate the advantageous effects of the present invention, two mechanical simulation models are established, wherein one is the background art, and the other is the method of the present invention. The geometric sizes, materials and boundary conditions of the panels in the two simulation models are the same. During the operation of the antenna, 70% of the external load comes from gravity. Therefore, according to the two models, two representative working conditions are selected, i.e., an x-direction gravity analysis and a y-direction gravity analysis.
- (2) Calculation results. As illustrated in
Figs. 12 to 15 ,Figs. 12 and 13 are gravity deformation diagrams of an antenna panel in x-direction and y-direction in the background art, respectively.Figs. 14 and 15 are gravity deformation diagrams of an antenna panel in x-direction and y-direction in the present invention, respectively. - (3) Implementation effects. As illustrated in Table 1, it can be seen from the calculation results that in the background art, a maximum gravity deformation of the panel in the x-direction is 61.5 µm and a maximum gravity deformation thereof in the y-direction is 49.9 µm. In the present invention, a maximum gravity deformation of the panel in the x-direction is 27.1 µm, and a maximum gravity deformation thereof in the y-direction is 24.5 µm. Since the adjustment mechanism in the present invention includes a lateral support to the panel, the deformation of the panel is greatly improved, and the deformations in the x-direction and y-direction are substantially equal, with a change rate of only 9.6%, while in the background art the change rate is 18.9%. Compared with the background art, improvement rates of the maximum deformations of the panel in the x-direction and y-direction are 55.9% and 50.9% respectively in the present invention.
- The final implementation effect of the present invention is further illustrated by a mechanical simulation analysis:
- (1) Calculation content. The calculation content is the gravity deformation of the sub-reflector of the dual-offset antenna in the elevation range of 0° to 90°. The calculated elevation angles comprise 0°, 15°, 30°, 45°, 50°, 60°, 75° and 90°.
- (2) Calculation results. According to the calculated deformation data of the sub-reflector, a precision analysis is carried out to obtain the surface accuracy of the sub-reflector at different elevation angles.
Figs. 16 and 17 are gravity deformation diagrams of a sub-reflector at different elevation angles, andFig. 18 illustrates surface accuracy of a sub-reflector at different elevation angles. From the calculation results, it can be seen that the surface accuracy of the sub-reflector is greater than 52 µm in the elevation range of 0° to 90°, which is very suitable for the dual-offset antenna working in a high frequency band. - To sum up, the sub-reflector device of the present invention comprises an adjustment device, a sub-reflector, a single-layer space frame backup structure and a panel precise adjustment device. The adjustment device adopts movable and fixed platforms as a multi-rod six-degree-of-freedom sub-reflector adjustment mechanism for a plane truss to realize a primary pose adjustment of the sub-reflector. The sub-reflector is composed of a polygonal panel and several sectorial panels, and an area of each sectorial panel is substantially equal to that of the polygonal panel. The numbers of inner and outer sides of the single-layer space frame backup structure is in a ratio of 1: 2, which provides a support stiffness for the sub-reflector. The panel precise adjustment device comprises a positioning mechanism for adjusting the panel in a normal direction and an adjustment mechanism for adjusting a movement of the sub-reflector. Such a sub-reflector device not only realizes a two-stage position and pose adjustment of the sub-reflector, but also improves the integral stiffness and reduces the overall weight of the sub-reflector system, while improving the installation and adjustment efficiency and reducing the manufacturing cost.
| Compared content | Background art | Method of the present invention |
| Maximum gravity deformation in x-direction | 61.5µm | 27.1µm |
| Maximum gravity deformation in y-direction | 49.9µm | 24.5µm |
| Relative rate of x\y deformations in the background art | 18.9% | |
| Relative rate of x\y deformations in the present invention | 9.6% | |
| Maximum deformation improvement rate in the present invention | Gravity in x-direction | 55.9% |
| Gravity in y-direction | 50.9% | |
Claims (25)
- A uniformly-partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function, comprising an adjustment device (1), a sub-reflector (2), a single-layer space frame backup structure (3) and a panel precise adjustment device (4);wherein the adjustment device (1) is located in a direction of an aperture of the sub-reflector (2) and comprises a movable platform (1-1), a fixed platform (1-2), a primary adjustment rod (1-3), an auxiliary adjustment rod (1-4), a movable platform spherical joint (1-5) and a fixed platform spherical joint (1-6); the movable platform (1-1) is connected to the single-layer space frame backup structure (3), and the fixed platform (1-2) is located outside the aperture of the sub-reflector (2); the fixed platform (1-2) is a plane truss structure with an N-polygonal shape, wherein N is a natural number and N≥4; the fixed platform (1-2) is composed of N fixed platform rods (1-2-1 to 1-2-N), every two of which are connected by the fixed platform spherical joint (1-6); the movable platform (1-1) is a plane truss structure with a 2N-polygonal shape, and is composed of 2N movable platform rods (1-1-1 to 1-1-2N), every two of which are connected by the movable platform spherical joint (1-5); the movable platform rod (1-1-1 to 1-1-2N), the fixed platform rod (1-2-1 to 1-2-N), the primary adjustment rod (1-3) and the auxiliary adjustment rod (1-4) form a mesh structure with a plurality of triangular space regions;the sub-reflector (2) is composed of an N-polygonal panel (2-1) and N sectorial panels (2-2), with the N sectorial panels (2-2) being radially distributed around the N-polygonal panel (2-1) and each having an area substantially equal to that of the N-polygonal panel (2-1), and the sub-reflector (2) being connected to the single-layer space frame backup structure (3) through the panel precise adjustment device (4);the single-layer space frame backup structure (3) is composed of an inner ring support (3-1), a main rod (3-2), a diagonal rod (3-3) and an inner ring spherical joint (3-4); wherein the inner ring support (3-1) has an N-polygonal shape and is composed of N inner ring rods (3-1-1 to 3-1-N), every two of which are connected to each other through the inner ring spherical joint (3-4); the inner ring rod (3-1-1), the movable platform rod (1-1-1 to 1-1-2N), the main rod (3-2) and the diagonal rod (3-3) form a mesh structure with a plurality of triangular space regions;the panel precise adjustment device (4) comprises a positioning mechanism (4-1) and an adjustment mechanism (4-2), with the positioning mechanism (4-1) being located at connection points between the N-polygonal panel (2-1) and the inner ring spherical joint (3-4) of the single-layer space frame backup structure (3), and connection points between the N sectorial panels (2-2) and the inner ring spherical joint (3-4) of the single-layer space frame backup structure (3); and the adjustment mechanism (4-2) being located at a non-working side of an antenna panel.
- The uniformly-partitioned high-precision sub-reflector device according to claim 1, wherein an included angle between a plane where the movable platform (1-1) is located and a plane where the fixed platform (1-2) is located is 0° to 30°.
- The uniformly-partitioned high-precision sub-reflector device according to claim 2, wherein at least one of the N fixed platform spherical joints (1-6) is corresponding to the movable platform spherical joint (1-5).
- The uniformly-partitioned high-precision sub-reflector device according to claim 3, wherein the primary adjustment rod (1-3) is composed of N rod, with two ends connected to the movable platform spherical joint (1-5) and the fixed platform spherical joint (1-6), respectively, and the number of the primary adjustment rods (1-3) is N.
- The uniformly-partitioned high-precision sub-reflector device according to claim 4, wherein two ends of the auxiliary adjustment rod (1-4) are connected to the movable platform spherical joint (1-5) and the fixed platform spherical joint (1-6), respectively, and the number of the auxiliary adjustment rods (1-4) is 2N.
- The uniformly-partitioned high-precision sub-reflector device according to claim 5, wherein each of the primary adjustment rod (1-3) and the auxiliary adjustment rod (1-4) comprises spherical hinges located at the two ends thereof, and a threaded structure with an adjustable length located in the middle thereof.
- The uniformly-partitioned high-precision sub-reflector device according to claim 6, wherein the inner ring support (3-1) and the movable platform (1-1) are respectively located in two planes with a distance of 500 mm to 3000 mm therebetween.
- The uniformly-partitioned high-precision sub-reflector device according to claim 7, wherein at least one of the N inner ring spherical joints (3-4) is corresponding to the movable platform spherical joint (1-5).
- The uniformly-partitioned high-precision sub-reflector device according to claim 8, wherein two ends of the main rod (3-2) are connected to the inner ring spherical joint (3-4) and the movable platform spherical joint (1-5), respectively, and the number of the main rods (3-2) is N.
- The uniformly-partitioned high-precision sub-reflector device according to claim 9, wherein two ends of the diagonal rod (3-3) are connected to the inner ring spherical joint (3-4) and the movable platform spherical joint (1-5), respectively, and the number of the diagonal rods (3-3) is 2N.
- The uniformly-partitioned high-precision sub-reflector device according to claim 10, wherein the positioning mechanism (4-1) is composed of a main supporting rod (4-1-1), an independent supporting rod (4-1-2), a first direction connection plate (4-1-3), a second direction connection plate (4-1-4), a screw nut (4-1-5), a spherical washer (4-1-6) and a conical washer (4-1-7); wherein an axial direction of the main supporting rod (4-1-1) is the same as a normal direction of the panel at the position of the main supporting rod (4-1-1); the first direction connection plate (4-1-3) is connected to the single-layer space frame backup structure (3) through the main supporting rod (4-1-1); the second direction connection plate (4-1-4) is connected to the panel through a fastener or glue; and the independent supporting rod (4-1-2) is located between the first direction connection plate (4-1-3) and the second direction connection plate (4-1-4).
- The uniformly-partitioned high-precision sub-reflector device according to claim 11, wherein the first direction connection plate (4-1-3) and the second direction connection plate (4-1-4) are provided with oblong holes having extending directions orthogonal to each other.
- The uniformly-partitioned high-precision sub-reflector device according to claim 12, wherein an upper end of the independent supporting rod (4-1-2) is located in the oblong hole of the second direction connection plate (4-1-4) and fixed by the screw nut (4-1-5), and a lower end of the independent supporting rod (4-1-2) is located in the oblong hole of the first direction connection plate (4-1-3) and fixed by the screw nut (4-1-5), the spherical washer (4-1-6), and the conical washer (4-1-7).
- The uniformly-partitioned high-precision sub-reflector device according to claim 13, wherein the adjustment mechanism (4-2) is composed of a V-shaped rod (4-2-1), a unidirectional rod (4-2-2), a dual-joint support (4-2-3) and a single-joint support (4-2-4); wherein the V-shaped rod (4-2-1) comprises an A-link (4-2-1-1) and a B-link (4-2-1-2) with adjustable lengths and each having spherical hinges at two ends; one end of each of the A-link (4-2-1-1) and the B-link (4-2-1-2) is connected to the single-layer space frame backup structure (3), and the other end thereof is connected to the dual-joint support (4-2-3); the unidirectional rod (4-2-2) has an adjustable length and provided with spherical hinges at two ends thereof, wherein one end is connected to the single-layer space frame backup structure (3), and the other end is connected to the single-joint support (4-2-4).
- The uniformly-partitioned high-precision sub-reflector device according to claim 14, wherein an adjustment amount of the panel by the adjustment mechanism (4-2) satisfies the following equations:


- The uniformly-partitioned high-precision sub-reflector device according to claim 15, wherein an adjustment amount of the A-link and the B-link in a y-direction satisfies the following equation:

- The uniformly-partitioned high-precision sub-reflector device according to claim 16, wherein an adjustment amount of the unidirectional rod in the x-direction and an adjustment amount of the unidirectional rod in the y-direction satisfy the following equations:

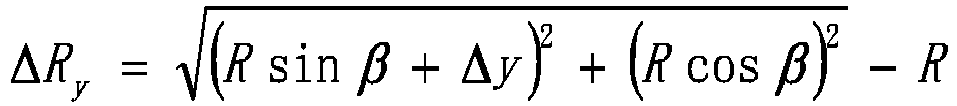
- The uniformly-partitioned high-precision sub-reflector device according to claim 17, wherein a ratio of a maximum curved surface area to a minimum curved surface area among the N-polygonal panel (2-1) and the N sectorial panels (2-2) is 1 to 1.3.
- The uniformly-partitioned high-precision sub-reflector device according to claim 18, wherein an intermediate threaded structure of the primary adjustment rod (1-3) and the auxiliary adjustment rod (1-4) has an adjustable length and has left-handed and right-handed threads in combination.
- The uniformly-partitioned high-precision sub-reflector device according to claim 19, wherein the spherical hinges at the two ends of each of the primary adjustment rod (1-3) and the auxiliary adjustment rod (1-4) are ball bearings.
- The uniformly-partitioned high-precision sub-reflector device according to claim 20, wherein the inner ring rod (3-1-1 to 3-1-N), the movable platform rod (1-1-1 to 1-1-2N), the main rod (3-2) and the diagonal rod (3-3) each comprises a circular tube, a conical head, a high-strength bolt and a screw nut.
- The uniformly-partitioned high-precision sub-reflector device according to claim 21, wherein an intermediate threaded structure of the A-link (4-2-1-1), the B-link (4-2-1-2) and the unidirectional rod (4-2-2) has an adjustable length and has left-handed and right-handed threads in combination.
- The uniformly-partitioned high-precision sub-reflector device according to claim 22, wherein the screw nut (4-1-5), the spherical washer (4-1-6) and the conical washer (4-1-7) are symmetrically distributed on two sides of the first direction connection plate (4-1-3).
- The uniformly-partitioned high-precision sub-reflector device according to claim 23, wherein the dual-joint support (4-2-3) is located at a center of gravity of the antenna panel and connected thereto through a fastener or glue; and the single-joint support (4-2-4) is located under the antenna panel and connected thereto through a fastener or glue.
- The uniformly-partitioned high-precision sub-reflector device according to claim 24, wherein a gap between the N-polygonal panel (2-1) and the N sectorial panels (2-2) constituting the sub-reflector (2) is 0.2 mm to 5 mm.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE19939758.9T DE19939758T1 (en) | 2019-07-26 | 2019-12-16 | Uniformly partitioned high-precision sub-reflector device with a two-stage position and pose adjustment function |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201910682977.9A CN110289498B (en) | 2019-07-26 | 2019-07-26 | Uniformly divided high-precision sub-reflector device with two-level posture adjustment function |
| PCT/CN2019/125478 WO2021017373A1 (en) | 2019-07-26 | 2019-12-16 | Uniformly-partitioned high-precision sub-reflector device with two-stage pose adjustment function |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP4007071A1 EP4007071A1 (en) | 2022-06-01 |
| EP4007071A4 EP4007071A4 (en) | 2023-10-18 |
| EP4007071B1 true EP4007071B1 (en) | 2024-11-20 |
Family
ID=68022505
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP19939758.9A Active EP4007071B1 (en) | 2019-07-26 | 2019-12-16 | Uniformly-partitioned high-precision sub-reflector device with two-stage pose adjustment function |
Country Status (6)
| Country | Link |
|---|---|
| EP (1) | EP4007071B1 (en) |
| CN (1) | CN110289498B (en) |
| DE (1) | DE19939758T1 (en) |
| ES (1) | ES2921899T3 (en) |
| WO (1) | WO2021017373A1 (en) |
| ZA (1) | ZA202202438B (en) |
Families Citing this family (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110289498B (en) * | 2019-07-26 | 2024-02-13 | 中国电子科技集团公司第五十四研究所 | Uniformly divided high-precision sub-reflector device with two-level posture adjustment function |
| CN111478054B (en) * | 2020-05-18 | 2024-03-05 | 中国科学院国家天文台 | FAST reflecting surface unit self-adaptive connection mechanism and layout method |
| CN112018523B (en) * | 2020-09-28 | 2024-11-22 | 中国电子科技集团公司第五十四研究所 | Inflatable spliced antenna |
| CN114050421B (en) * | 2021-08-19 | 2023-08-22 | 中国工程物理研究院应用电子学研究所 | Two-dimensional beam-scanning high-power microwave offset-fed dual-reflector antenna system and its application |
| CN113839211B (en) * | 2021-08-30 | 2023-05-19 | 电子科技大学 | A Cassegrain Monopulse Antenna Based on Planar Array Structure |
| CN118380750B (en) * | 2024-06-14 | 2025-04-01 | 南京驰韵科技发展有限公司 | A satellite-borne reflector antenna adjustment control system |
| CN118746915A (en) * | 2024-06-17 | 2024-10-08 | 集美大学 | A Stewart platform attitude control method, device and medium |
| CN119681556B (en) * | 2025-02-27 | 2025-04-25 | 中色十二冶金建设有限公司 | Auxiliary positioning structure for installation of large-span spherical steel net frame |
Family Cites Families (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN202004142U (en) | 2010-12-16 | 2011-10-05 | 中国电子科技集团公司第五十四研究所 | Positioning connection device of combined antenna panel |
| CN202712431U (en) * | 2012-08-27 | 2013-01-30 | 中国电子科技集团公司第五十四研究所 | Antenna sub-reflector system comprising fixed adjusting mechanism |
| US10241321B1 (en) * | 2015-05-06 | 2019-03-26 | Sciperio, Inc | Monolithic adaptive optical/RF reflector |
| CN105226370A (en) | 2015-10-23 | 2016-01-06 | 上海创投机电工程有限公司 | 6/6-UPU type parallel mechanism antenna structure system |
| CN106450653B (en) * | 2016-09-08 | 2023-05-09 | 中国电子科技集团公司第五十四研究所 | A parallel six-degree-of-freedom redundant driving antenna structure system |
| CN108155482B (en) * | 2017-12-25 | 2023-08-15 | 中国电子科技集团公司第五十四研究所 | Structure and adjustment method of a high-precision reflector antenna combination panel |
| CN108172970A (en) | 2018-01-31 | 2018-06-15 | 中国电子科技集团公司第五十四研究所 | An antenna panel assembly structure |
| CN109301452B (en) * | 2018-09-19 | 2024-02-02 | 中国科学院遥感与数字地球研究所 | S/X/Ka triaxial antenna |
| CN110289498B (en) * | 2019-07-26 | 2024-02-13 | 中国电子科技集团公司第五十四研究所 | Uniformly divided high-precision sub-reflector device with two-level posture adjustment function |
| CN210040562U (en) * | 2019-07-26 | 2020-02-07 | 中国电子科技集团公司第五十四研究所 | Uniformly divided high-precision sub-reflector device with two-stage pose adjustment function |
-
2019
- 2019-07-26 CN CN201910682977.9A patent/CN110289498B/en active Active
- 2019-12-16 EP EP19939758.9A patent/EP4007071B1/en active Active
- 2019-12-16 WO PCT/CN2019/125478 patent/WO2021017373A1/en not_active Ceased
- 2019-12-16 DE DE19939758.9T patent/DE19939758T1/en active Pending
- 2019-12-16 ES ES19939758T patent/ES2921899T3/en active Active
-
2022
- 2022-02-25 ZA ZA2022/02438A patent/ZA202202438B/en unknown
Also Published As
| Publication number | Publication date |
|---|---|
| ES2921899T1 (en) | 2022-09-02 |
| ES2921899T8 (en) | 2025-05-16 |
| DE19939758T1 (en) | 2022-09-01 |
| CN110289498A (en) | 2019-09-27 |
| EP4007071A1 (en) | 2022-06-01 |
| CN110289498B (en) | 2024-02-13 |
| ES2921899T3 (en) | 2025-05-06 |
| EP4007071A4 (en) | 2023-10-18 |
| WO2021017373A1 (en) | 2021-02-04 |
| ZA202202438B (en) | 2023-11-29 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP4007071A1 (en) | Uniformly-partitioned high-precision sub-reflector device with two-stage pose adjustment function | |
| CN105740554B (en) | A kind of large-scale deformation parabola antenna panel precision regulation method towards gain | |
| CN109449604B (en) | High-precision hexagonal space double-layer reflecting surface antenna back frame | |
| Duan et al. | Reflector antenna distortion analysis using MEFCM | |
| CN109301452B (en) | S/X/Ka triaxial antenna | |
| CN108155482B (en) | Structure and adjustment method of a high-precision reflector antenna combination panel | |
| Clarricoats et al. | Design and performance of a reconfigurable mesh reflector antenna. Part 1: Antenna design | |
| CN101635390B (en) | Final-assembly die with truss type spatial structure | |
| CN113740806B (en) | Three-sided corner reflector and using method thereof | |
| US20230052062A1 (en) | Reflective surface antenna based on triple telescopic rod drive and quasi-geodesic grid structure | |
| CN104682011A (en) | Ground reflector in cable network structure | |
| US20040027309A1 (en) | Preloaded parabolic dish antenna and the method of making it | |
| EP2941796A1 (en) | Configurable backing structure for a reflector antenna and corrective synthesis for mechanical adjustment thereof | |
| CN210040562U (en) | Uniformly divided high-precision sub-reflector device with two-stage pose adjustment function | |
| CN106654510B (en) | A large working space variable drive parallel antenna base mechanism | |
| AU2001278672A1 (en) | Preloaded parabolic dish antenna and the method of making it | |
| CN108110431B (en) | Reflecting surface installation adjustment method of reflecting surface antenna | |
| CN105576385B (en) | Towards gain method of adjustment is rotated with being directed toward large-scale deformation parabola antenna panel and coincideing | |
| JP2853815B2 (en) | Direction adjustment mount for antenna tower suitable for satellite communication antenna | |
| CN115663468A (en) | Vehicle-mounted spherical phased-array antenna | |
| EP4382965A1 (en) | Dihedral corner reflector and method of use thereof | |
| US3725946A (en) | Radio antenna structure | |
| CN209913042U (en) | Multi-rod six-degree-of-freedom auxiliary surface adjusting device with movable platform and fixed platform as planar truss | |
| CN110289476B (en) | High-precision position and attitude continuous adjustment device for reflective surface antenna panel and manufacturing method thereof | |
| CN209913023U (en) | High-precision pose continuous adjusting device of reflecting surface antenna panel |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE INTERNATIONAL PUBLICATION HAS BEEN MADE |
|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20220225 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref legal event code: R210 Ref country code: DE Ref legal event code: R210 Ref document number: 602019062438 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: BA2A Ref document number: 2921899 Country of ref document: ES Kind code of ref document: T1 Effective date: 20220902 |
|
| DAV | Request for validation of the european patent (deleted) | ||
| DAX | Request for extension of the european patent (deleted) | ||
| REG | Reference to a national code |
Ipc: H01Q0019190000 Ref country code: DE Ref legal event code: R079 Ref document number: 602019062438 Country of ref document: DE Free format text: PREVIOUS MAIN CLASS: H01Q0015160000 Ipc: H01Q0019190000 |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: H01Q 15/16 20060101ALN20230904BHEP Ipc: H01Q 3/20 20060101ALN20230904BHEP Ipc: H01Q 15/14 20060101ALI20230904BHEP Ipc: H01Q 19/19 20060101AFI20230904BHEP |
|
| A4 | Supplementary search report drawn up and despatched |
Effective date: 20230918 |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: H01Q 15/16 20060101ALN20230912BHEP Ipc: H01Q 3/20 20060101ALN20230912BHEP Ipc: H01Q 15/14 20060101ALI20230912BHEP Ipc: H01Q 19/19 20060101AFI20230912BHEP |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: H01Q 15/16 20060101ALN20240610BHEP Ipc: H01Q 3/20 20060101ALN20240610BHEP Ipc: H01Q 15/14 20060101ALI20240610BHEP Ipc: H01Q 19/19 20060101AFI20240610BHEP |
|
| INTG | Intention to grant announced |
Effective date: 20240710 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| P01 | Opt-out of the competence of the unified patent court (upc) registered |
Free format text: CASE NUMBER: APP_56215/2024 Effective date: 20241015 |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602019062438 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R082 Ref document number: 602019062438 Country of ref document: DE Representative=s name: HERNANDEZ, YORCK, DIPL.-ING., DE |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250320 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250320 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MK05 Ref document number: 1744444 Country of ref document: AT Kind code of ref document: T Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250220 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250221 Ref country code: AT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250220 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 2921899 Country of ref document: ES Kind code of ref document: T3 Effective date: 20250506 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: PL |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20241216 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602019062438 Country of ref document: DE |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20241231 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20241231 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20241231 |
|
| 26N | No opposition filed |
Effective date: 20250821 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20241216 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20250220 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20250930 Year of fee payment: 7 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250220 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20251121 Year of fee payment: 7 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20260116 Year of fee payment: 7 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |