EP0767129B1 - Bobbin supply system - Google Patents
Bobbin supply system Download PDFInfo
- Publication number
- EP0767129B1 EP0767129B1 EP19960115242 EP96115242A EP0767129B1 EP 0767129 B1 EP0767129 B1 EP 0767129B1 EP 19960115242 EP19960115242 EP 19960115242 EP 96115242 A EP96115242 A EP 96115242A EP 0767129 B1 EP0767129 B1 EP 0767129B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- bobbin
- bobbins
- magazine
- full
- tray
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Lifetime
Links
- 238000003780 insertion Methods 0.000 claims description 14
- 230000037431 insertion Effects 0.000 claims description 14
- 238000004804 winding Methods 0.000 claims description 12
- 230000002950 deficient Effects 0.000 claims description 9
- 238000000034 method Methods 0.000 claims description 7
- 230000005484 gravity Effects 0.000 claims description 3
- 230000032258 transport Effects 0.000 claims 2
- 210000000078 claw Anatomy 0.000 description 6
- 238000000926 separation method Methods 0.000 description 3
- 238000001514 detection method Methods 0.000 description 2
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H67/00—Replacing or removing cores, receptacles, or completed packages at paying-out, winding, or depositing stations
- B65H67/06—Supplying cores, receptacles, or packages to, or transporting from, winding or depositing stations
- B65H67/069—Removing or fixing bobbins or cores from or on the vertical peg of trays, pallets or the pegs of a belt
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2701/00—Handled material; Storage means
- B65H2701/30—Handled filamentary material
- B65H2701/31—Textiles threads or artificial strands of filaments
Definitions
- the present invention relates to a bobbin supply system according to the preamble of claim 1.
- Such a system is known from JP-A-05-221512.
- This automatic system comprises a horizontal bobbin belt conveyor feeding the bobbins into a drum reservoir having horizontal receiving openings from where the bobbins fall into a chute with its lower part facing down by gravity after having been checked by a top and bottom distinguishing device.
- the problem underlying the present invention is to provide a system of the above mentioned type having an uncomplicated structure and being usable by an operator.
- (1) is a bobbin supply device, the structure of which will be described hereafter.
- (2) is a tray and the tray (2) is transported by a transport line in a state where a bobbin is loaded on to it.
- (3) is a bobbin removal device and is so constructed that it removes all the bobbins transported along a tray return line (7) from the aforementioned trays (2).
- (4) is a yarn end finding device which positions the yarn end of the bobbin in a predetermined position on the bobbin so that auto-yarn joining can be performed by the auto-winder (5)
- (11) is a separation device that sends the defective bobbins (B1) that have failed the yarn end finding process to the defective bobbin transport line (10) and the full bobbins (Bf) that have successfully completed the yarn end finding process to the tray supply line (14).
- (12) is a control device that controls all of the winding units of the auto-winder and the bobbin supply system.
- a transport line using a belt conveyor is used for the transport of trays (2).
- the transport lines from each winding unit of the auto-winder (5) to the bobbin supply device (1) are called the tray return lines (6,7,8), the transport lines as far as each winding unit of the auto-winder (5) is concerned and which supply bobbins to the trays (2) by the bobbin supply device (1) are called the tray supply lines (9,14) and the transport line of defective bobbins (81) is called the defective bobbin transport line (10).
- each winding unit of the auto-winder (5) transport of the full bobbins (Bf) by a conveyor while loaded on the tray (2), rewinding of the yarn from the full bobbin (Bf) to the winding packages and ejection of the empty bobbin (Be) (including residual yarn bobbins) is carried out.
- the empty bobbin or residual yarn bobbins (Be) ejected by each winding unit of the auto-winder (5) is transported to the tray return line (6) while loaded on the tray (2).
- the empty bobbin or residual yarn bobbin (Be) loaded on the trays (2) enter the tray return line (7) where the bobbin removal device (3) is positioned, are removed from the tray (2) by the friction of the removal belt of the bobbin removal device (3) and ejected to the bobbin storage box (19).
- the bobbin supply device (1) is arranged along the tray return line (8).
- the trays (2) are temporarily stopped by a stopper (13), full bobbins (Bf) are supplied with the bottom side (Bb) facing downwards by the bobbin chute (18) and the trays (2) with the full bobbins (Bf) are transported to the tray supply line (9).
- a bottom bunch cutting device (101) that cuts the bottom bunch wind on the base of the bobbin, a back wind yarn cutting device (102) that cuts the back wound yarn wound on the outer layer of the bobbin and the yarn end finding device (4) are arranged in sequential order from the bobbin supply device (I) along the tray supply line (9). Those that have successfully completed yarn end finding are sent to the tray supply line (14) via the separation device (11).
- the full bobbins (Bf) which have failed the yarn end finding process are sent to the defective bobbin transport line (10) by the switching of the separation device (11) by the control device (12) which receives a yarn end finding failure signal from the yarn end finding device (4).
- the aforementioned defective bobbin transport line (10) is connected to the tray return line (7) and the defective bobbins (B1) are removed from the trays (2) by the bobbin removal device (3) without exception.
- the defective bobbins (B1) and the empty bobbin or residual yarn bobbin (Be) all enter the bobbin storage box (19) in a mixed state.
- the bobbins which have entered the storage box (19) are differentiated from the bobbins having enough yarn remaining to be wound off by the auto-winder and other bobbins by the operator.
- the bobbins (B1) which can be rewound are supplied to the magazine (20) of the bobbin supply device (1) after procedures are carried out to facilitate the yarn end finding process by the operator.
- the storage box (19) is positioned inside the operator's operating space (S) where supply of bobbins to the magazine (20) is carried out.
- the bobbins removed by the bobbin removal device (3) are sent to the storage box (19) inside the operation space (S). Accordingly, the operator need only take out the rewindable bobbins from the storage box (19) in the operating space (S) and supply them to the magazine (20) after correcting them.
- the bobbin supply device (1) is provided with the magazine (20) and the bobbin chute (18).
- a spur gear (30) is arranged to stop the rotation of the spur gear (29) with the number of teeth being the same as the spur gear (29).
- the spur gear (29) and the spur gear (30) are fixed by a bolt (not shown) so that they are stacked vertically and are made to rotate simultaneously.
- a arm (25) is supported by the support point (34) of the rod (23) of the cylinder (21) and the rotating shaft (33) being a fixed point. Furthermore, a claw (27) corresponding to the ratchet spur gear (29) is supported so as to be freely rotatable by the support point (31).
- a arm (26) is supported by the support point (35) of the rod (24) of the cylinder (22) and a support point (32) being a fixed point. Yet further, the support point (32) supports so as to be freely rotatable a claw (28) which is a stopper of the spur gear (30).
- the magazine (20) comprises a cylindrical bobbin insertion member (42) which is arranged with a same number of the cylindrical bobbin insertion holes (37) having a diameter larger than the winding diameter of the full bobbin (Bf) as the number of teeth as the spur gear (29) on a circle concentric with the rotating shaft (33) of the spur gear (29), a bobbin reception member (43) that has a bobbin delivery opening (38) cut away only directly above the bobbin chute (18) and enough so that there is no hindrance to droppage of the full bobbin (Bf), and that drive part.
- the aforementioned bobbin insertion member (42) and the bobbin reception member (43) comprise a stocker for individualising and stocking the bobbins.
- the drive part is provided with the aforementioned spur gears (29,30).
- the tray (2) from which the bobbin has been taken by the bobbin removal device (3) is transported by the tray return line (8) and stopped by the bobbin stopper (13) in a predetermined position where the full bobbin (Bf) can be reliably loaded on the empty tray from the bobbin chute (18).
- a tray detection sensor (15) operates and sends a signal to the control device (12). Due to the signal of the control device (12), the bobbin chute (18) goes from a open state (18a) being a standby state, to an closed state (18b) for guiding the full bobbin (Bf) to the tray (2).
- a bobbin detection sensor (16) sends a signal to the control device (12), a signal is sent from the control device (12) and the bobbin chute (18) goes to the open state (18a) also being the standby state. Furthermore, a signal is also sent to the stopper (13), the stopper (13) separates from the full bobbin (Bf) and the full bobbin (Bf) proceeds along the tray return line (8) while loaded on the tray (2).
- the number of bobbins insertable into the magazine (20) of a first embodiment of the present invention is (24) but may be changed according to the scale of the operation.
Landscapes
- Replacing, Conveying, And Pick-Finding For Filamentary Materials (AREA)
- Spinning Or Twisting Of Yarns (AREA)
Description
- The present invention relates to a bobbin supply system according to the preamble of claim 1.
- Such a system is known from JP-A-05-221512. This automatic system comprises a horizontal bobbin belt conveyor feeding the bobbins into a drum reservoir having horizontal receiving openings from where the bobbins fall into a chute with its lower part facing down by gravity after having been checked by a top and bottom distinguishing device.
- The problem underlying the present invention is to provide a system of the above mentioned type having an uncomplicated structure and being usable by an operator.
- This problem is solved by the features included in the characterizing portion of claim 1. Such a system is reliable in operation and may be operated by an operator who enters new full bobbins and also rejected bobbins if usable in the magazine.
-
- Figure 1 is a front view of the bobbin supply system of the present invention,
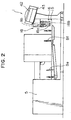
- Figure 2 is a side view of the bobbin supply system, and
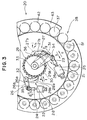
- Figure 3 is an enlarged view of the main part of the magazine of the present invention.
- (1) is a bobbin supply device, the structure of which will be described hereafter. (2) is a tray and the tray (2) is transported by a transport line in a state where a bobbin is loaded on to it. (3) is a bobbin removal device and is so constructed that it removes all the bobbins transported along a tray return line (7) from the aforementioned trays (2). (4) is a yarn end finding device which positions the yarn end of the bobbin in a predetermined position on the bobbin so that auto-yarn joining can be performed by the auto-winder (5) (11) is a separation device that sends the defective bobbins (B1) that have failed the yarn end finding process to the defective bobbin transport line (10) and the full bobbins (Bf) that have successfully completed the yarn end finding process to the tray supply line (14). (12) is a control device that controls all of the winding units of the auto-winder and the bobbin supply system.
- A transport line using a belt conveyor is used for the transport of trays (2). The transport lines from each winding unit of the auto-winder (5) to the bobbin supply device (1) are called the tray return lines (6,7,8), the transport lines as far as each winding unit of the auto-winder (5) is concerned and which supply bobbins to the trays (2) by the bobbin supply device (1) are called the tray supply lines (9,14) and the transport line of defective bobbins (81) is called the defective bobbin transport line (10).
- Hereafter the flow of the bobbins supplied to and returned from each winding unit of the auto-winder (5) will be described.
- At each winding unit of the auto-winder (5), transport of the full bobbins (Bf) by a conveyor while loaded on the tray (2), rewinding of the yarn from the full bobbin (Bf) to the winding packages and ejection of the empty bobbin (Be) (including residual yarn bobbins) is carried out. The empty bobbin or residual yarn bobbins (Be) ejected by each winding unit of the auto-winder (5) is transported to the tray return line (6) while loaded on the tray (2).
- In continuance, the empty bobbin or residual yarn bobbin (Be) loaded on the trays (2) enter the tray return line (7) where the bobbin removal device (3) is positioned, are removed from the tray (2) by the friction of the removal belt of the bobbin removal device (3) and ejected to the bobbin storage box (19).
- The bobbin supply device (1) is arranged along the tray return line (8). The trays (2) are temporarily stopped by a stopper (13), full bobbins (Bf) are supplied with the bottom side (Bb) facing downwards by the bobbin chute (18) and the trays (2) with the full bobbins (Bf) are transported to the tray supply line (9).
- A bottom bunch cutting device (101) that cuts the bottom bunch wind on the base of the bobbin, a back wind yarn cutting device (102) that cuts the back wound yarn wound on the outer layer of the bobbin and the yarn end finding device (4) are arranged in sequential order from the bobbin supply device (I) along the tray supply line (9). Those that have successfully completed yarn end finding are sent to the tray supply line (14) via the separation device (11).
- Further, the full bobbins (Bf) which have failed the yarn end finding process are sent to the defective bobbin transport line (10) by the switching of the separation device (11) by the control device (12) which receives a yarn end finding failure signal from the yarn end finding device (4).
- The aforementioned defective bobbin transport line (10) is connected to the tray return line (7) and the defective bobbins (B1) are removed from the trays (2) by the bobbin removal device (3) without exception. The defective bobbins (B1) and the empty bobbin or residual yarn bobbin (Be) all enter the bobbin storage box (19) in a mixed state.
- The bobbins which have entered the storage box (19) are differentiated from the bobbins having enough yarn remaining to be wound off by the auto-winder and other bobbins by the operator. The bobbins (B1) which can be rewound are supplied to the magazine (20) of the bobbin supply device (1) after procedures are carried out to facilitate the yarn end finding process by the operator.
- The storage box (19) is positioned inside the operator's operating space (S) where supply of bobbins to the magazine (20) is carried out. The bobbins removed by the bobbin removal device (3) are sent to the storage box (19) inside the operation space (S). Accordingly, the operator need only take out the rewindable bobbins from the storage box (19) in the operating space (S) and supply them to the magazine (20) after correcting them.
- Then, full bobbins (Bf) which are loaded on the tray (2) and have finished the yarn end finding process are transported to each winding unit of the auto-winder (5) from the tray supply line (14).
- The bobbin supply device (1) is provided with the magazine (20) and the bobbin chute (18). A spur gear (29), being one.part of the drive part of the magazine (20), forms a ratchet with the number of teeth being the same as the number of the bobbin insertion holes (37) for inserting the full bobbins (Bf). A spur gear (30) is arranged to stop the rotation of the spur gear (29) with the number of teeth being the same as the spur gear (29). The spur gear (29) and the spur gear (30) are fixed by a bolt (not shown) so that they are stacked vertically and are made to rotate simultaneously.
- A arm (25) is supported by the support point (34) of the rod (23) of the cylinder (21) and the rotating shaft (33) being a fixed point. Furthermore, a claw (27) corresponding to the ratchet spur gear (29) is supported so as to be freely rotatable by the support point (31). A arm (26) is supported by the support point (35) of the rod (24) of the cylinder (22) and a support point (32) being a fixed point. Yet further, the support point (32) supports so as to be freely rotatable a claw (28) which is a stopper of the spur gear (30).
- The magazine (20) comprises a cylindrical bobbin insertion member (42) which is arranged with a same number of the cylindrical bobbin insertion holes (37) having a diameter larger than the winding diameter of the full bobbin (Bf) as the number of teeth as the spur gear (29) on a circle concentric with the rotating shaft (33) of the spur gear (29), a bobbin reception member (43) that has a bobbin delivery opening (38) cut away only directly above the bobbin chute (18) and enough so that there is no hindrance to droppage of the full bobbin (Bf), and that drive part. The aforementioned bobbin insertion member (42) and the bobbin reception member (43) comprise a stocker for individualising and stocking the bobbins. Also, the drive part is provided with the aforementioned spur gears (29,30).
- The tray (2) from which the bobbin has been taken by the bobbin removal device (3) is transported by the tray return line (8) and stopped by the bobbin stopper (13) in a predetermined position where the full bobbin (Bf) can be reliably loaded on the empty tray from the bobbin chute (18).
- When the tray (2) stops, a tray detection sensor (15) operates and sends a signal to the control device (12). Due to the signal of the control device (12), the bobbin chute (18) goes from a open state (18a) being a standby state, to an closed state (18b) for guiding the full bobbin (Bf) to the tray (2).
- When the rod (24) of the cylinder (22) is pushed in direction (c) by a signal from the control device (12), the arm (26) supported by the connected support point (35) moves to position (26b) in direction (c) and the connected claw (28) moves higher than the height of the tooth of the spur gear (29) to position (28b) in direction (e) so that spur gears (29,30) become able to rotate.
- When the rod (23) of the cylinder (21) is pushed in the direction (a) by a signal from the control device (12), the arm (25) supported by the support point (31) moves to position (25b) in direction (g) with the rotating shaft (33) as a support point, the claw (27) moves to position (27b) by the force of the cylinder (21) rotating the spur gear (29) in direction (g) being an anticlockwise direction and the bobbin insertion member (42) is rotated in the anticlockwise direction (g) by one tooth, in short, by one bobbin insertion hole (37).
- Following that, when the rod (24) of the cylinder (22) is returned in direction d by a signal from the control device (12), the arm (26) supported by the support point (35) moves to position (26a) and the claw (28) moves to position (28a) where restriction of the movement of the spur gear (30) is possible by movement in direction (f).
- Further, when the rod (23) of the cylinder (21) is pushed in the direction (b) by a signal from the control device (12), the arm (25) moves to position (25a) in a direction opposite direction (g) and the claw (27) moves in direction (h) along the surface (36) of the teeth of the spur gear (29) stopping in position (27a).
- When the bobbin insertion member (42) rotates by one the bobbin insertion hole (37), a new full bobbin (Bf) drops by gravity from the bobbin delivery opening (38) and is loaded onto the tray (2) after passing through the bobbin chute (18).
- When the full bobbin (Bf) has been loaded, a bobbin detection sensor (16) sends a signal to the control device (12), a signal is sent from the control device (12) and the bobbin chute (18) goes to the open state (18a) also being the standby state. Furthermore, a signal is also sent to the stopper (13), the stopper (13) separates from the full bobbin (Bf) and the full bobbin (Bf) proceeds along the tray return line (8) while loaded on the tray (2).
- The above operations are repeated and the full bobbin (Bf) is supplied to the empty tray (2) but as for the insertion of the full bobbin (Bf) in the magazine (20), the operator must determine the top/bottom of the full bobbin (Bf) and insert one bobbin (Bf) at a time into the bobbin insertion hole (37) with the bottom side (Bb) facing downwards.
- Further, the number of bobbins insertable into the magazine (20) of a first embodiment of the present invention is (24) but may be changed according to the scale of the operation.
Claims (1)
- A bobbin supply system comprising a tray supply line that transports trays to each winding unit of a winding machine from a bobbin supply system (1) that supplies full bobbins (Bf) at a time through a chute (18) to the trays (2); a return line (6, 8) that transports the trays from the winding unit to the bobbin supply system (1) having a magazine (20) which is rotatable around a rotating axis and which stocks the full bobbins (Bf); said magazine (20) comprising cylindrical bobbin insertion members (42) having cylindrical insertion holes (37) and a fixed bobbin reception member (43) with a bobbin delivery opening (38) associated with the top of the chute (18), whereby a full bobbin (Bf) can drop by gravity from the bobbin delivery opening (38) for being loaded onto a tray (2) after passing through the chute (18);
characterized in that
at the rearward end of the bobbin supply system next to the magazine (20) an operating space (S) is provided in such a position that full bobbins (Bf) can be manually and individually inserted through the operating space (S) into the insertion holes (37);
a storage box (19) is provided in the operating space (S) where bobbins having residual yarn and full bobbins defective as to yarn end finding are entered by a bobbin removal device (3) from the return line (6, 7, 8) and from where the residual yarn bobbins and the bobbins which can be rewound are supplied to the magazine (20) after procedures are carried out to facilitate yarn end finding by an operator,
the magazine (20) is inclined in the revert direction, and
the bobbin insertion members (42) are provided in a number according to the scale of operation.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP7257590A JP2943668B2 (en) | 1995-10-04 | 1995-10-04 | Bobbin supply system |
| JP257590/95 | 1995-10-04 |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP0767129A2 EP0767129A2 (en) | 1997-04-09 |
| EP0767129A3 EP0767129A3 (en) | 1997-12-17 |
| EP0767129B1 true EP0767129B1 (en) | 2006-05-17 |
Family
ID=17308388
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP19960115242 Expired - Lifetime EP0767129B1 (en) | 1995-10-04 | 1996-09-23 | Bobbin supply system |
Country Status (4)
| Country | Link |
|---|---|
| EP (1) | EP0767129B1 (en) |
| JP (1) | JP2943668B2 (en) |
| CN (1) | CN1103311C (en) |
| DE (1) | DE69636136T2 (en) |
Families Citing this family (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2001089033A (en) | 1999-09-21 | 2001-04-03 | Murata Mach Ltd | Automatic winder |
| JP2009024298A (en) * | 2007-07-23 | 2009-02-05 | Toyota Industries Corp | Bobbin supply device in spinning machine |
| DE102008055847A1 (en) * | 2008-11-04 | 2010-05-06 | Oerlikon Textile Gmbh & Co. Kg | Pallete device |
| CN102078863A (en) * | 2010-06-21 | 2011-06-01 | 刘士法 | Automatic-spooler type hollow pipe sorter |
| JP2012184074A (en) | 2011-03-04 | 2012-09-27 | Murata Machinery Ltd | Feed yarn bobbin supply device and automatic winder |
| CN102895517B (en) * | 2012-09-17 | 2014-10-29 | 刘增智 | Method for preparing qi-tonifying and hair-blacking medicine, and medicine prepared by using same method |
| CN103508161A (en) * | 2013-09-22 | 2014-01-15 | 青岛宏大纺织机械有限责任公司 | Bobbin yarn conveying device of automatic winder |
| JP2016003089A (en) * | 2014-06-13 | 2016-01-12 | 村田機械株式会社 | Automatic winder and thread winding method |
| JP2016155631A (en) * | 2015-02-24 | 2016-09-01 | 村田機械株式会社 | Yarn feeding bobbin direction conversion device and bobbin supply system |
| JP2017053047A (en) * | 2015-09-08 | 2017-03-16 | 村田機械株式会社 | Yarn winding device, automatic winder including the device, textile machine system including the winder, and yarn feeding bobbin abnormality detection method |
| JP2017082370A (en) * | 2015-10-30 | 2017-05-18 | 村田機械株式会社 | Bobbin turnaround mechanism, bobbin storage device and spinning machine |
| JP2018008794A (en) * | 2016-07-14 | 2018-01-18 | 村田機械株式会社 | Yarn feeding bobbin direction conversion device and yarn feeding bobbin discharge device |
| CN106192089A (en) * | 2016-09-22 | 2016-12-07 | 江苏凯宫机械股份有限公司 | Intelligence combing bobbin automatic feeding mechanism |
| JP2019052033A (en) * | 2017-09-15 | 2019-04-04 | 村田機械株式会社 | Bobbin supply device and bobbin processing system |
| DE102017123777A1 (en) * | 2017-10-12 | 2019-04-18 | Saurer Spinning Solutions Gmbh & Co. Kg | Bobbin and tube transport system for an automatic winder |
| CN107938046B (en) * | 2017-11-23 | 2023-05-16 | 青岛宏大纺织机械有限责任公司 | Device and method for discharging empty tube in intubation |
Family Cites Families (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5961163U (en) * | 1982-10-13 | 1984-04-21 | 村田機械株式会社 | Tube supply device |
| US5226778A (en) * | 1989-09-28 | 1993-07-13 | Murata Kikai Kabushiki Kaisha | Yarn supply device for automatic winder |
| DE4029894A1 (en) * | 1990-09-21 | 1992-03-26 | Schlafhorst & Co W | WINDING MACHINE THAT CAN BE LOADED BY HAND WITH COILS |
| JPH058944A (en) * | 1991-06-29 | 1993-01-19 | Murata Mach Ltd | Automatic winder thread supply system |
| JPH05221512A (en) * | 1992-02-10 | 1993-08-31 | Murata Mach Ltd | Bobbin feeder |
| JPH0665582A (en) * | 1992-08-19 | 1994-03-08 | Hitachi Zosen Corp | Equipment for dechlorination and separation of waste plastic |
| JPH0780632A (en) * | 1993-09-16 | 1995-03-28 | Kubota Corp | Molten metal holding furnace |
-
1995
- 1995-10-04 JP JP7257590A patent/JP2943668B2/en not_active Expired - Fee Related
-
1996
- 1996-09-23 EP EP19960115242 patent/EP0767129B1/en not_active Expired - Lifetime
- 1996-09-23 DE DE1996636136 patent/DE69636136T2/en not_active Expired - Lifetime
- 1996-10-03 CN CN96119954A patent/CN1103311C/en not_active Expired - Fee Related
Also Published As
| Publication number | Publication date |
|---|---|
| JP2943668B2 (en) | 1999-08-30 |
| CN1152538A (en) | 1997-06-25 |
| EP0767129A3 (en) | 1997-12-17 |
| JPH09100067A (en) | 1997-04-15 |
| CN1103311C (en) | 2003-03-19 |
| DE69636136D1 (en) | 2006-06-22 |
| EP0767129A2 (en) | 1997-04-09 |
| DE69636136T2 (en) | 2007-04-19 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US4463909A (en) | Cop supplying system in automatic winder | |
| US4576341A (en) | Cop transporting systems for an automatic winder | |
| US4586668A (en) | Bobbin conveying system | |
| EP0767129A2 (en) | Bobbin supply system | |
| US5588603A (en) | Yarn take-up tube supplying apparatus for a winder | |
| US4613091A (en) | Cop transporting system for an automatic winder | |
| CH660380A5 (en) | BOBBIN DELIVERY DEVICE WITH A TRANSPORTER CONNECTING A SPINNING MACHINE WITH A REEL. | |
| EP0262726A2 (en) | Equipment and process to supply winding tubes to the individual collection stations of a textile machine | |
| US4688735A (en) | Paper tube supply system | |
| US4610406A (en) | Bobbin supplying system | |
| US4676061A (en) | Empty bobbin transporting system | |
| JPS6210902B2 (en) | ||
| US4724666A (en) | Device for keeping a constant number of bobbin tubes in circulation between a spinning machine and a winding machine | |
| US5289674A (en) | Winding machine with an in-line package preparer, and an improved spinning-winding method | |
| JPH06100245A (en) | Pipe thread feeder | |
| JPS6397583A (en) | Bobbin transport system | |
| JPH0616226A (en) | Pipe thread feeder | |
| JPS639051B2 (en) | ||
| JPH0219212B2 (en) | ||
| EP0463695B1 (en) | Machine for preparing yarn packages and corresponding method | |
| JPS6113007B2 (en) | ||
| JPH0155186B2 (en) | ||
| JPH07101537A (en) | Winding tube supply device | |
| EP1167265A2 (en) | Magazine for tubes of a textile machine | |
| JPS60153372A (en) | Bobbin conveying system |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Kind code of ref document: A2 Designated state(s): DE FR IT |
|
| PUAL | Search report despatched |
Free format text: ORIGINAL CODE: 0009013 |
|
| AK | Designated contracting states |
Kind code of ref document: A3 Designated state(s): DE FR IT |
|
| 17P | Request for examination filed |
Effective date: 19980210 |
|
| 17Q | First examination report despatched |
Effective date: 19980804 |
|
| APAB | Appeal dossier modified |
Free format text: ORIGINAL CODE: EPIDOS NOAPE |
|
| APAB | Appeal dossier modified |
Free format text: ORIGINAL CODE: EPIDOS NOAPE |
|
| APAD | Appeal reference recorded |
Free format text: ORIGINAL CODE: EPIDOS REFNE |
|
| APAB | Appeal dossier modified |
Free format text: ORIGINAL CODE: EPIDOS NOAPE |
|
| APBJ | Interlocutory revision of appeal recorded |
Free format text: ORIGINAL CODE: EPIDOS IRAPE |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| APAF | Appeal reference modified |
Free format text: ORIGINAL CODE: EPIDOSCREFNE |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): DE FR IT |
|
| REF | Corresponds to: |
Ref document number: 69636136 Country of ref document: DE Date of ref document: 20060622 Kind code of ref document: P |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed |
Effective date: 20070220 |
|
| EN | Fr: translation not filed | ||
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20070309 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20060517 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20090922 Year of fee payment: 14 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20090926 Year of fee payment: 14 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100923 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R119 Ref document number: 69636136 Country of ref document: DE Effective date: 20110401 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110401 |