WO2024150372A1 - ソフトウェア更新システム、管制センタ、およびソフトウェア更新装置 - Google Patents
ソフトウェア更新システム、管制センタ、およびソフトウェア更新装置 Download PDFInfo
- Publication number
- WO2024150372A1 WO2024150372A1 PCT/JP2023/000617 JP2023000617W WO2024150372A1 WO 2024150372 A1 WO2024150372 A1 WO 2024150372A1 JP 2023000617 W JP2023000617 W JP 2023000617W WO 2024150372 A1 WO2024150372 A1 WO 2024150372A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- update
- software
- data
- vehicle
- external environment
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F8/00—Arrangements for software engineering
- G06F8/60—Software deployment
- G06F8/65—Updates
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/01—Detecting movement of traffic to be counted or controlled
- G08G1/0104—Measuring and analyzing of parameters relative to traffic conditions
- G08G1/0108—Measuring and analyzing of parameters relative to traffic conditions based on the source of data
- G08G1/0112—Measuring and analyzing of parameters relative to traffic conditions based on the source of data from the vehicle, e.g. floating car data [FCD]
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/01—Detecting movement of traffic to be counted or controlled
- G08G1/0104—Measuring and analyzing of parameters relative to traffic conditions
- G08G1/0125—Traffic data processing
- G08G1/0133—Traffic data processing for classifying traffic situation
Definitions
- the present invention relates to a software update system, a control center, and a software update device for updating software in an external environment recognition device.
- External recognition devices installed on vehicles and other moving objects recognize road structures such as traffic lights and road signs that exist around the vehicle, but if the recognition accuracy is low, the recognition software of the external recognition device needs to be updated.
- Patent Document 1 is a background technology in this technical field.
- Patent Document 1 relates to an information processing device, information processing method, and information processing system that enable appropriate updates of software used for driving assistance or automatic driving of a mobile body.
- the information processing device is characterized in that it includes a recognition unit that performs recognition processing of the situation around the mobile body based on sensor data related to the situation around the mobile body, and a software update control unit that controls updates of software used for driving assistance or automatic driving of the mobile body based on the recognition result of the recognition processing.
- paragraph 0133 of Patent Document 1 states, "For example, the software update control unit 261 determines whether or not an update of the software for autonomous driving, etc. is necessary based on the recognition results of various recognition processes performed by the recognition unit 73. If the software update control unit 261 determines that an update of the software for autonomous driving, etc. is necessary, it transmits recognition processing information including the recognition results by the recognition unit 73 to the management server 211 via the communication unit 22 and the network 212.”
- paragraph 0157 of Patent Document 1 states, "In step S34, the object recognition unit 281 determines whether or not the recognition accuracy has decreased. For example, a recognition score threshold is set in advance for each object class through a prior learning process. The object recognition unit 281 compares the calculated recognition score with the corresponding threshold for each object recognized in the process of step S31. If there is an object whose recognition score is less than the threshold, the object recognition unit 281 determines that the recognition accuracy has decreased, and the process proceeds to step S35."
- the information processing device described in Patent Document 1 compares the recognition score of a recognized object with a recognition score threshold that is preset by prior learning processing in the object recognition unit, and if it determines that the recognition accuracy has decreased, it controls the update of software used for driving assistance or autonomous driving of a mobile object.
- the deterioration in recognition accuracy is judged based on the recognition score, it is difficult to grasp the deterioration in accuracy regarding the relative position between the recognition target and the vehicle.
- the need for a software update is determined by the software update processing unit installed in the vehicle, making it difficult to distinguish whether the problem is specific to the vehicle or a problem with the recognition software.
- the present invention was made in consideration of the above problems, and its purpose is to provide a software update system, a control center, and a software update device that can determine with high accuracy whether or not the software of an external recognition device needs to be updated.
- the present invention provides a software update system including a software update device that updates the software of an external environment recognition device mounted on a vehicle, and a control center that communicates with the software update device via a network and distributes update software used to update the software of the external environment recognition device, the software update device includes a vehicle-side transmission unit that transmits external environment recognition data generated by the external environment recognition device to the control center, and the control center includes an update necessity determination unit that determines whether or not the software needs to be updated based on the external environment recognition data.
- the present invention provides a control center that communicates with a software update device that updates the software of an external environment recognition device mounted on a vehicle via a network and distributes update software used to update the software of the external environment recognition device, the control center receiving unit receiving external environment recognition data generated by the external environment recognition device from the software update device, an update necessity determination unit determining whether or not the software needs to be updated based on the external environment recognition data, an update data storage unit storing update data including the external environment recognition data and raw data of the external environment sensor used to generate the external environment recognition data, an update software generation unit generating the update software using the update data, and a notification unit notifying the software update device of the location where the update data used to generate the update software was obtained when the update necessity determination unit determines that the software needs to be updated.
- the present invention also provides a software update device that communicates via a network with a control center that distributes update software used to update the software of an external environment recognition device mounted on a vehicle, the software update device comprising: a vehicle-side transmitting unit that transmits external environment recognition data generated by the external environment recognition device to the control center; a vehicle-side update data storage unit that stores update data including the external environment recognition data and raw data of an external environment sensor used to generate the external environment recognition data; and a vehicle-side receiving unit that receives from the control center an acquisition location of the update data that the control center uses to generate the update software, and after the vehicle-side receiving unit receives the acquisition location, the vehicle-side update data storage unit stores the update data acquired at the acquisition location, and the vehicle-side transmitting unit transmits the update data acquired at the acquisition location that is stored in the vehicle-side update data storage unit to the control center.
- control center determines whether the software of the external environment recognition device needs to be updated based on the external environment recognition data generated by the external environment recognition device, making it possible to determine with high accuracy whether the software of the external environment recognition device needs to be updated.
- FIG. 1 is a diagram illustrating an example of an overall configuration of a software update system according to an embodiment of the present invention.
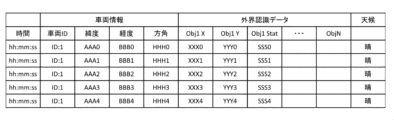
- FIG. 13 is a diagram showing time-series data of update data.
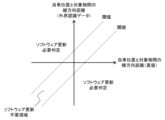
- 13A and 13B are diagrams illustrating an example of a software update necessity determination based on a vertical distance.
- 13A and 13B are diagrams illustrating an example of a determination of the necessity of a software update in terms of a horizontal distance.
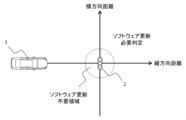
- FIG. 13 is a diagram showing an example of software update necessity determination in a bird's-eye view.
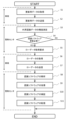
- FIG. 1 is a diagram illustrating an example of a flowchart of a software update system according to an embodiment of the present invention.
- FIG. 1 is a diagram showing an example of the overall configuration of a vehicle 1 and a control center 200 according to an embodiment of the present invention.
- the vehicle 1 shown in FIG. 1 has an external environment recognition device 10, a vehicle information acquisition device 20, and a software update device 30.
- the software update device 30 has a microcomputer, a storage device, and a communication interface.
- the microcomputer is a processor (e.g., a CPU) that executes a program stored in the storage device.
- the microcomputer operates as a functional unit that provides various functions by executing a specific program.
- the storage device includes a non-volatile storage area and a volatile storage area.
- the non-volatile storage area includes a program area that stores the program executed by the microcomputer, and a data area that temporarily stores data used by the microcomputer when executing the program.
- the volatile storage area stores data used by the microcomputer when executing the program.
- the communication interface connects to other electronic control devices via a network such as CAN or Ethernet.
- the control center 200 is a device that determines whether or not the software of the external environment recognition device 10 needs to be updated, and if it is determined that an update is necessary, carries out the software update. It has an update necessity determination unit 210, an update software generation unit 220, a feature data storage unit 230, a control center side update data storage unit 240, a recognition software database 250, a control center side receiving unit 260, and a notification unit 270.
- the external environment recognition device 10 generates external environment recognition data related to road features such as road structures (traffic lights, road signs, road markings, etc.) and road conditions (road width, road surface condition, etc.) around the vehicle 1 based on the results of observation of the external environment by external environment sensors 40 mounted on the vehicle 1, such as a camera sensor using an image sensor and a radar sensor using millimeter waves or lasers, and outputs the data to the software update device 30. It also extracts image data, video data, and point cloud data from the external environment sensors 40 used to generate the external environment recognition data, and outputs the data to the software update device 30.
- road features traffic lights, road signs, road markings, etc.
- road conditions road width, road surface condition, etc.
- the vehicle information acquisition device 20 acquires vehicle information relating to the operation of the vehicle 1, such as the running speed and steering angle of the vehicle 1, based on the output of vehicle sensors such as a speed sensor and steering angle sensor mounted on the vehicle 1, and outputs this to the software update device 30. It also acquires the current position and current attitude of the vehicle 1 based on information from the GPS (Global Positioning System), GNSS (Global Navigation Satellite System), gyro sensor, etc., and outputs this to the software update device 30.
- GPS Global Positioning System
- GNSS Global Navigation Satellite System
- gyro sensor Global Navigation Satellite System
- the software update device 30 is a device that transmits update data including the external recognition data, raw data, vehicle position data, and vehicle direction data acquired from the external recognition device 10 and the vehicle information acquisition device 20 to the control center 200, receives recognition software (update software) of the external recognition device 10 distributed from the control center 200, and performs software updates of the external recognition device 10, and has a vehicle-side transmitting unit 31, a vehicle-side receiving unit 32, and a vehicle-side update data storage unit 33.
- the software update device 30 is specifically a microcomputer mounted on an ECU (Electronic Control Unit) equipped with a CPU and memory (ROM, RAM), and is a device that realizes each function by the CPU executing various programs stored in the memory.
- ECU Electronic Control Unit
- the vehicle-side update data storage unit 33 stores the update data acquired from the external environment recognition device 10 and the vehicle information acquisition device 20.
- the update data includes, for example, external environment recognition data, vehicle position data, and vehicle direction data.
- the vehicle-side receiving unit 32 receives information on the raw data acquisition location via the notification unit 270, and the vehicle-side update data storage unit 33 stores the update data including the external environment recognition data, raw data, vehicle position data, and vehicle direction data when the vehicle 1 travels through the raw data acquisition location.
- the update data stored in the vehicle-side update data storage unit 33 is transmitted to the control center-side receiving unit 260 via the vehicle-side transmitting unit 31, and stored in the control center-side update data storage unit 240.
- the update data stored in the vehicle-side update data storage unit 33 is time-series data, and includes vehicle information, external recognition data, raw data, etc.
- vehicle information includes a vehicle ID, vehicle position data, vehicle direction data, etc.
- the external recognition data includes data such as the relative position between the vehicle 1 and an object.
- the vehicle position data includes, for example, latitude and longitude information.
- the vehicle direction data may include the direction in which the vehicle 1 is facing, as well as the attitude of the vehicle.
- the vehicle ID is assigned to determine which vehicle 1 the external recognition data was acquired from.
- the external recognition data includes the vertical distance and horizontal distance from the object, the type of the object, status information, etc.
- the external recognition data includes object information related to at least one object.
- the raw data includes the video, images, point cloud data, etc. used to generate the external recognition data, stored in time series. Since the recognition accuracy of the external recognition device 10 is affected by the weather, weather information may be included in the raw data and stored as shown in FIG. 2.
- the vehicle-side update data storage unit 33 acquires raw data from the external environment recognition device 10 based on the raw data acquisition location received via the notification unit 270, but raw data may be acquired in stages according to the analysis process by the update software generation unit 220 described below. For example, raw data may be acquired all the time when traveling through the location, then raw data may be acquired by narrowing down the time period, and finally raw data may be acquired by narrowing down the time period and weather conditions, for example.
- the control center 200 may notify the update software generation unit 220 of the location and time of raw data acquisition according to the analysis, improvement, and verification process via the notification unit 270.
- the update data is time-series data, but the data can be divided into a variety of sections. For example, it may be data from when the external environment recognition device 10 recognizes an object to when it goes out of the recognition range of the external environment recognition device 10, or data from when the vehicle 1 starts (EGN on or power on) to when it stops (EGN off or power off), or data for a specific time (for example, in one-minute increments).
- the vehicle-side update data storage unit 33 may be a storage device provided in an on-board device installed in the vehicle 1, or may be an external storage device such as an SD card or removable disk connected to the vehicle 1.
- the software update device 30 transmits update data to the control center 200 via the vehicle-side transmitter 31.
- There are a variety of transmission methods including a method using a wireless communication device installed in the vehicle 1, a wireless communication method such as a Wi-Fi connection at a facility where the vehicle 1 stops, such as at home, a convenience store, or a gas station, or a method in which the data is stored in an external storage device and communicated via the Internet from a terminal such as a PC or smartphone.
- the update necessity determination unit 210 determines whether or not the external environment recognition device 100 is updated based on the feature data acquired from the infrastructure 300 and stored in the feature data storage unit 230 and the update data stored in the control center side update data storage unit 240.
- the recognition accuracy calculation unit 211 determines whether or not the recognition software of the vehicle 10 needs to be updated.
- a determination method in the case where the external recognition data is the relative position from the vehicle 1 to a feature will be specifically described. Based on the vehicle position data, vehicle direction data, and feature data included in the update data, a true value of the relative position from the vehicle 1 to the feature is calculated, and a difference between the true value and the external environment recognition data included in the update data is calculated.
- the error amount exceeds a preset threshold value.
- the threshold value may be set according to the specifications of the external environment recognition device 10, or may be set statistically.
- the above describes a method for determining whether or not the recognition software needs to be updated based on the comparison result between the external recognition data and the true value.
- the method for determining whether or not the recognition software needs to be updated is not limited to this.
- the determination may be made based on a comparison result between another parameter calculated based on the vehicle position data, the vehicle direction data, and the feature data and a true value of the parameter.
- the true value of the vertical distance between the vehicle position and the feature i.e., the distance in the forward and backward directions as seen from the vehicle 1 is compared with the external recognition data.
- the horizontal axis is the true value and the vertical axis is the external recognition data, if the error is small, it is mapped to an area where a software update is not required, and if the error is large, it is mapped to an area where a software update is required, and it is possible to determine whether or not a software update is required.
- the threshold value for the area where a software update is required and the area where it is not required may be determined according to the specifications of the external recognition device 10, or may be set statistically. Generally, the further away an object is, the lower the recognition accuracy becomes, so the threshold value may be set to be relaxed.
- the true value of the lateral distance between the vehicle position and the feature i.e., the distance from the left to right as seen from the vehicle 1 is compared with the external recognition data.
- the true value on the horizontal axis and the external recognition data on the vertical axis if the error is small, it is mapped to an area where a software update is not required, and on the other hand, if the error is large, it is mapped to an area where a software update is required, and it is possible to determine whether or not a software update is required.
- the threshold value for the area where a software update is required and the area where it is not required may be determined based on the specifications of the external recognition device 10, or may be set statistically. Generally, the further away an object is, the lower the recognition accuracy becomes, so the threshold value may be set to be relaxed.
- the true values of the vertical and horizontal distances between the vehicle position and the feature are compared with the external recognition data.
- a road structure 2 such as a traffic light is installed in front of the vehicle 1.
- the thresholds for the area where software update is required and the area where it is not required may be determined according to the specifications of the external recognition device 10, or may be set statistically.
- the thresholds shown in FIG. 5 are displayed on a perfect circle, but they may also be displayed as ellipses depending on the characteristics of the external recognition device 10.
- the determination of whether or not the recognition software needs to be updated is made when the amount of error in the external recognition data exceeds a threshold value when multiple vehicles 1 are in the same location. This is because it is determined that the scene in that location is difficult for the recognition software to recognize, and that the software needs to be improved. On the other hand, if only a specific vehicle exceeds the threshold value, it can be determined that there is a problem specific to the vehicle (such as a deviation due to aging) rather than the recognition software.
- the raw data acquisition location determination unit 212 determines that the recognition software needs to be updated, it requests the vehicle 1 to acquire the raw data required to update the recognition software. Specifically, it extracts locations where the amount of error in the external environment recognition data exceeds a threshold in multiple vehicles 1, and transmits these to the vehicle-side receiving unit 32 of the vehicle 1 via the notification unit 270.
- the raw data acquisition location is set based on the acquired vehicle direction data and road shape in a range away from the location where a feature with low recognition accuracy is installed, or in cases where the orientation in which the feature can be recognized is limited due to the traveling direction of the vehicle 1, such as a sign or traffic light.
- the raw data acquisition location is transmitted to the vehicle 1 equipped with the recognition software determined to need to be updated.
- the recognition software needs to be updated based on the external recognition data of multiple vehicles 1, it is possible to accurately identify locations that are difficult for the recognition software to recognize, and obtain raw data to deal with scenes that are difficult to recognize. Furthermore, because the processing is based on the external recognition data of multiple vehicles 1, it is possible to determine whether the problem is with the recognition software or a problem specific to a particular vehicle.
- the update software generation unit 220 analyzes, improves, and verifies the recognition software when the update necessity determination unit 210 determines that an update of the recognition software is necessary, and distributes the updated software to the vehicle 1, and is equipped with a recognition software analysis unit 221, a recognition software improvement unit 222, and a recognition software verification unit 223.
- the recognition software database 250 stores the version history and change history of the recognition software, and transmits recognition software information to the recognition software update unit when the recognition software is analyzed, improved, and verified.
- the update software generation unit 220 may request the required raw data from the vehicle 1 depending on the process status of the analysis, improvement, and update of the recognition software.
- the recognition software analysis unit 221 performs an analysis of the recognition software based on the update data that can be obtained from the control center side update data storage unit 240.
- the raw data of the update data includes image data, video data, point cloud data, etc. used to generate external recognition data.
- the version of the recognition software to be updated is obtained from the recognition software database 250, the raw data is input to the recognition software, and it is analyzed whether recognition is performed reliably. For example, by using update data that the update necessity determination unit 210 has determined to require a software update, it is possible to focus the analysis on scenes where the recognition software had low recognition accuracy.
- the analysis results are sent to the recognition software improvement unit 222, and include causes of low recognition accuracy such as the feature being recognized but the relative distance not being calculated correctly, the feature not being recognized, the feature having an unusual shape, or an obstruction between the feature and the vehicle 1.
- the recognition software improvement unit 222 improves the recognition software based on the analysis results obtained from the recognition software analysis unit 221. Specifically, additional learning of the recognition software is performed using update data, and parameters for calculating the relative distance between the vehicle 1 and features are updated. The improved software is sent to the recognition software verification unit 223.
- the recognition software verification unit 223 verifies the recognition software improved by the recognition software improvement unit 222. Specifically, it verifies whether improvements have been made in scenes where the improved recognition software is problematic. It also refers to the update history of the recognition software stored in the recognition software database 250 to check whether there are any problems with the changes made to the previous recognition software. If it is determined as a result of the verification that there are no problems with the improved recognition software, it stores it in the recognition software database 250 as the latest version and distributes the recognition software to the vehicle 1 via the notification unit 270.
- steps S1 and S2 external recognition data relating to features such as road structures present around the vehicle 1, and vehicle position data and vehicle direction data at the time of acquiring the external recognition data are acquired by the external recognition device 10 and vehicle information acquisition device 20 of the vehicle 1, and are stored in the vehicle-side update data storage unit 33.
- the update data including the external recognition data, vehicle position data, and vehicle direction data stored in the vehicle-side update data storage unit 33, is transmitted to the control center 200 via the vehicle-side transmission unit 31.
- step S3 the control center 200 stores the update data transmitted from the vehicle 1 in the control center update data storage unit 240 via the control center receiving unit 260.
- the update necessity determination unit 210 uses the update data stored in the control center update data storage unit 240 and the feature data stored in the feature data storage unit 230 to calculate the accuracy of the external environment recognition data included in the update data in the recognition accuracy calculation unit 211.
- step S4 it is determined whether or not the recognition software needs to be updated based on the accuracy of the external recognition data calculated in step S3. If it is determined that an update is necessary, the process proceeds to step S5. If it is determined that an update is not necessary, the process ends, and it is determined whether or not the recognition software needs to be updated for the next external recognition data.
- the raw data acquisition location determination unit 212 determines the raw data acquisition location required for updating the recognition software. Basically, the raw data acquisition location is the location where the external recognition data determined to need updating was acquired. The raw data acquisition location is notified to the vehicle 1 via the notification unit 270. The raw data acquisition location is also notified to multiple vehicles other than the vehicle that acquired the external recognition data.
- the software update device 30 stores the raw data acquisition location notified by the control center 200 in the vehicle-side update data storage unit 33 via the vehicle-side receiver 32.
- the external environment recognition device 10 normally transmits external environment recognition data to the software update device 30, but if the raw data acquisition location has been notified, when the vehicle 1 passes the raw data acquisition location, it also transmits the raw data used to generate the external environment recognition data to the software update device 30.
- the vehicle information acquisition device 20 also transmits vehicle position data and vehicle direction data to the software update device 30.
- the software update device 30 stores update data including the external environment recognition data, raw data, vehicle position data, and vehicle direction data acquired from the external environment recognition device 10 and the vehicle information acquisition device 20 in the vehicle-side update data storage unit 33.
- the software update device 30 transmits the update data to the control center 200 via the vehicle-side transmitter 31.
- step S8 the control center 200 stores the update data acquired via the control center receiving unit 260 in the control center update data storage unit 240.
- the recognition software analysis unit 221 uses the update data stored in the control center update data storage unit 240 to analyze the recognition software of the external environment recognition device 10. The analysis result is output to the recognition software improvement unit 222.
- step S9 the recognition software improvement unit 222 improves the recognition software of the external environment recognition device 10 based on the analysis results by the recognition software analysis unit 221.
- the improved recognition software is output to the recognition software verification unit 223.
- step S10 the recognition software verification unit 223 verifies the recognition software of the external environment recognition device 10 that has been improved by the recognition software improvement unit 222. If the verification results in a determination that there is no problem with the improved recognition software, it stores it in the recognition software database 250.
- step S11 the control center 200 distributes the latest recognition software stored in the recognition software database 250 to the vehicle 1 via the notification unit 270.
- the recognition accuracy calculation unit 211 compares the true value with the external recognition data, and when it is determined that the recognition software needs to be updated, the raw data acquisition location determination unit 212 sets the raw data acquisition location.
- a raw data acquisition request may be made to a vehicle 1 traveling in time periods such as early morning or twilight, or in order to improve the degradation of the recognition accuracy of the recognition software due to bad weather, a raw data acquisition request may be made to a vehicle 1 traveling in rainy or snowy weather.
- feature data is used to determine whether or not the recognition software needs to be updated, but the feature data stored in the feature data storage unit 230 does not necessarily determine the actual situation.
- the information stored in the feature data may differ from the actual road shape or the location of road structures due to road construction or natural disasters. Even in such a situation, it can be determined that the feature data is different based on the update data acquired by the vehicle 1. If it is determined that the feature data is different, the feature data may be updated, or processing may be performed such as not acquiring external environment recognition data related to features at that location.
- the software update device 30 includes a vehicle-side transmission unit 31 that transmits external environment recognition data generated by the external environment recognition device 10 to the control center 200, and the control center 200 includes an update necessity determination unit 210 that determines whether or not the software needs to be updated based on the external environment recognition data.
- control center 200 determines whether the software of the external environment recognition device 10 needs to be updated based on the external environment recognition data generated by the external environment recognition device 10, making it possible to determine with high accuracy whether the software of the external environment recognition device 10 needs to be updated.
- the control center 200 includes a control center side update data storage unit 240 that stores update data including the external recognition data and raw data of the external sensor 40 used to generate the external recognition data, an update software generation unit 220 that generates the update software using the update data, and a notification unit 270 that notifies the software update device 30 of the acquisition location of the update data when the update necessity determination unit 210 determines that the software needs to be updated.
- the software update device 30 includes a vehicle side update data storage unit 33 that stores the update data acquired at the acquisition location notified by the notification unit 270, and the vehicle side transmission unit 31 transmits the update data acquired at the acquisition location stored in the vehicle side update data storage unit 33 to the control center 200. This makes it possible to generate update software for the external recognition device 10 by investigating the cause of the decrease in recognition accuracy using raw data from a location where the software of the external recognition device 10 has difficulty recognizing.
- the notification unit 270 notifies the software update device 30 mounted on a vehicle other than the vehicle 1 that acquired the external environment recognition data of the acquisition location. This makes it possible to determine whether the deterioration of the recognition accuracy of the recognition software is due to a problem with the recognition software or a problem specific to a particular vehicle.
- the update data includes the position data and direction data of the vehicle 1 at the time the raw data was output. This makes it possible to determine whether or not the recognition software needs to be updated using the position data and direction data of the vehicle 1.
- control center 200 further includes a feature data storage unit 230 that stores feature data including position information of road features, and the update necessity determination unit 210 determines whether or not the software needs to be updated based on the external environment recognition data and the feature data. This makes it possible to determine with high accuracy whether or not the software of the external environment recognition device 10 needs to be updated.
- control center 200 communicates with the software update device 30, which updates the software of the external environment recognition device 10 mounted on the vehicle 1, via a network and distributes update software used to update the software of the external environment recognition device 10, and is equipped with a control center side receiving unit that receives external environment recognition data generated by the external environment recognition device 10 from the software update device 30, an update necessity determination unit 210 that determines whether or not the software needs to be updated based on the external environment recognition data, a control center side update data storage unit 240 that stores update data including the external environment recognition data and raw data of the external environment sensor 40 used to generate the external environment recognition data, an update software generation unit 220 that generates the update software using the update data, and a notification unit 270 that notifies the software update device 30 of the location where the update data used to generate the update software was obtained when the update necessity determination unit 210 determines that an update of the software is necessary.
- a control center side receiving unit that receives external environment recognition data generated by the external environment recognition device 10 from the software update device 30, an update necessity determination unit 210 that determines
- the software update device 30 communicates via a network with a control center 200 that distributes update software used to update the software of the external environment recognition device 10 installed in a vehicle, and includes a vehicle-side transmitting unit 31 that transmits external environment recognition data generated by the external environment recognition device 10 to the control center 200, a vehicle-side update data storage unit 33 that stores update data including the external environment recognition data and raw data of the external environment sensor 40 used to generate the external environment recognition data, and a vehicle-side receiving unit 32 that receives from the control center 200 the acquisition location of the update data used by the control center 200 to generate the update software, and after the vehicle-side receiving unit 32 receives the acquisition location, the vehicle-side update data storage unit 33 stores the update data acquired at the acquisition location, and the vehicle-side transmitting unit 31 transmits the update data acquired at the acquisition location stored in the vehicle-side update data storage unit 33 to the control center 200.
- a vehicle-side transmitting unit 31 that transmits external environment recognition data generated by the external environment recognition device 10 to the control center 200
- the present invention is not limited to the above-described embodiment, but includes various modified examples and equivalent configurations.
- the above-described embodiment has been described in detail to clearly explain the present invention, and the present invention is not necessarily limited to having all of the configurations described.
- each of the configurations, functions, processing units, processing means, etc. described above may be realized in part or in whole in hardware, for example by designing them as integrated circuits, or may be realized in software by a processor interpreting and executing a program that realizes each function.
- Information such as programs, tables, and files that realize each function can be stored in storage devices such as memory, hard disks, and SSDs (Solid State Drives), or in recording media such as IC cards, SD cards, and DVDs.
- storage devices such as memory, hard disks, and SSDs (Solid State Drives), or in recording media such as IC cards, SD cards, and DVDs.
- control lines and information lines shown are those considered necessary for explanation, and do not necessarily show all the control lines and information lines necessary for implementation. In reality, it is safe to assume that almost all components are interconnected.
Landscapes
- Engineering & Computer Science (AREA)
- Software Systems (AREA)
- General Engineering & Computer Science (AREA)
- Theoretical Computer Science (AREA)
- Computer Security & Cryptography (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Traffic Control Systems (AREA)
- Stored Programmes (AREA)
Abstract
Description
ソフトウェア更新装置30は、外界認識装置10と車両情報取得装置20から取得した外界認識データとローデータと自車位置データと自車方角データを含む更新用データを管制センタ200に送信し、管制センタ200より配信される外界認識装置10の認識ソフトウェア(更新ソフトウェア)を受信し、外界認識装置10のソフトウェア更新を実施する装置であり、車両側送信部31と、車両側受信部32と、車両側更新用データ記憶部33を有する。なお、ソフトウェア更新装置30は、具体的には、CPUやメモリ(ROM、RAM)を備えたECU(Electronic Control Unit)に搭載されたマイコンであり、メモリ内に格納された各種プログラムをCPUが実行することで、各機能を実現する装置である。
更新要否判定部210は、地物データ記憶部230に格納されたインフラ300より取得した地物データと、管制センタ側更新用データ記憶部240に格納された更新用データに基づき、外界認識装置10の認識ソフトウェアの更新要否を判定する。以下、外界認識データが車両1から地物までの相対位置である場合の判定方法を具体的に説明する。認識精度算出部211は、更新用データに含まれる車両位置データ及び車両方角データと地物データとに基づき、車両1から地物までの相対位置の真値を算出し、当該真値と更新用データに含まれる外界認識データとの差分(誤差量)を算出する。そして、誤差量があらかじめ設定した閾値を超えたか否かを判断する。例えば、図3から図5に例示するように、真値と外界認識データをグラフにマッピングして判定しても良い。ここで、閾値の設定は、外界認識装置10の仕様により定めても良いし、統計的に設定しても良い。以上、外界認識データと真値との比較結果に基づいて認識ソフトウェアの更新要否を判定する方法を説明したが、更新要否の判定方法はこれに限らず、外界認識データを基に算出される別のパラメータと、車両位置データと車両方角データと地物データとを基に算出される当該パラメータの真値との比較結果に基づいて判定しても良い。
更新ソフト生成部220は、更新要否判定部210において認識ソフトウェアの更新が必要と判定された場合に、認識ソフトウェアの解析、改善、検証を実施し、更新されたソフトウェアを車両1に配信し、認識ソフト解析部221、認識ソフト改善部222、認識ソフト検証部223を備える。認識ソフトデータベース250は、認識ソフトウェアのバージョン履歴や変更履歴が保管されており、認識ソフトウェアを解析・改善・検証を実施する際に、認識ソフト更新部に認識ソフトウェア情報を送信する。更新ソフト生成部220は、認識ソフトウェアの解析、改善、更新のプロセス状況に応じて必要なローデータを車両1に要求しても良い。
前述した実施形態では、認識精度算出部211において真値と外界認識データを比較し、認識ソフトウェアの更新が必要と判定した場合、ローデータ取得場所決定部212において、ローデータ取得場所を設定していたが、例えば、太陽の日差しによる認識ソフトウェアの認識精度低下を改善するために朝方や薄暮といった時間帯を走行する車両1に対してローデータ取得要求をしても良いし、悪天候による認識ソフトウェアの認識精度低下を改善するために雨や雪が降る天候の中走行する車両1に対してローデータ取得要求をしても良い。
本実施形態では、車両1に搭載された外界認識装置10のソフトウェアを更新するソフトウェア更新装置30と、ソフトウェア更新装置30とネットワークを介して通信を行い外界認識装置10のソフトウェア更新に用いる更新ソフトウェアを配信する管制センタ200とを含むソフトウェア更新システムにおいて、ソフトウェア更新装置30は、外界認識装置10により生成された外界認識データを管制センタ200に送信する車両側送信部31を備え、管制センタ200は、前記外界認識データに基づいて前記ソフトウェアの更新要否を判定する更新要否判定部210を備える。
Claims (7)
- 車両に搭載された外界認識装置のソフトウェアを更新するソフトウェア更新装置と、前記ソフトウェア更新装置とネットワークを介して通信を行い前記外界認識装置のソフトウェア更新に用いる更新ソフトウェアを配信する管制センタとを含むソフトウェア更新システムにおいて、
前記ソフトウェア更新装置は、
前記外界認識装置により生成された外界認識データを前記管制センタに送信する車両側送信部を備え、
前記管制センタは、前記外界認識データに基づいて前記ソフトウェアの更新要否を判定する更新要否判定部を備える
ことを特徴とするソフトウェア更新システム。 - 請求項1に記載されたソフトウェア更新システムにおいて、
前記管制センタは、
前記外界認識データと前記外界認識データの生成に用いられた外界センサのローデータとを含む更新用データを記憶する管制センタ側更新用データ記憶部と、
前記更新用データを用いて前記更新ソフトウェアを生成する更新ソフトウェア生成部と、
前記更新要否判定部が前記ソフトウェアの更新が必要と判定した場合に、前記更新用データの取得場所を前記ソフトウェア更新装置に通知する通知部とを備え、
前記ソフトウェア更新装置は、前記通知部から通知された前記取得場所において取得された前記更新用データを記憶する車両側更新用データ記憶部を備え、
前記車両側送信部は、前記車両側更新用データ記憶部に記憶された、前記取得場所において取得された前記更新用データを前記管制センタに送信する
ことを特徴とするソフトウェア更新システム。 - 請求項2に記載されたソフトウェア更新システムにおいて、
前記通知部は、前記外界認識データを取得した車両と異なる他車両に搭載された前記ソフトウェア更新装置に前記取得場所を通知する
ことを特徴とするソフトウェア更新システム。 - 請求項2に記載されたソフトウェア更新システムにおいて、
前記更新用データは、前記ローデータが出力された際の前記車両の位置データおよび方角データを含む
ことを特徴とするソフトウェア更新システム。 - 請求項1に記載されたソフトウェア更新システムにおいて、
前記管制センタは、道路地物の位置情報を含む地物データを記憶する地物データ記憶部をさらに備え、
前記更新要否判定部は、前記外界認識データと前記地物データとに基づいて前記ソフトウェアの更新要否を判定する
ことを特徴とするソフトウェア更新システム。 - 車両に搭載された外界認識装置のソフトウェアを更新するソフトウェア更新装置とネットワークを介して通信を行い前記外界認識装置のソフトウェア更新に用いる更新ソフトウェアを配信する管制センタにおいて、
前記外界認識装置により生成された外界認識データを前記ソフトウェア更新装置から受信する管制センタ側受信部と、
前記外界認識データに基づいて前記ソフトウェアの更新要否を判定する更新要否判定部と、
前記外界認識データと前記外界認識データの生成に用いられた外界センサのローデータとを含む更新用データを記憶する管制センタ側更新用データ記憶部と、
前記更新用データを用いて前記更新ソフトウェアを生成する更新ソフトウェア生成部と、
前記更新要否判定部が前記ソフトウェアの更新が必要と判定した場合に、前記更新ソフトウェアを生成するために用いる前記更新用データの取得場所を前記ソフトウェア更新装置に通知する通知部とを備える
ことを特徴とする管制センタ。 - 車両に搭載された外界認識装置のソフトウェア更新に用いる更新ソフトウェアを配信する管制センタとネットワークを介して通信を行うソフトウェア更新装置において、
前記外界認識装置により生成された外界認識データを前記管制センタに送信する車両側送信部と、
前記外界認識データと前記外界認識データの生成に用いられた外界センサのローデータとを含む更新用データを記憶する車両側更新用データ記憶部と、
前記管制センタが前記更新ソフトウェアを生成するために用いる前記更新用データの取得場所を前記管制センタから受信する車両側受信部とを備え、
前記車両側更新用データ記憶部は、前記車両側受信部が前記取得場所を受信した後に、前記取得場所において取得された前記更新用データを記憶し、
前記車両側送信部は、前記車両側更新用データ記憶部に記憶された、前記取得場所において取得された前記更新用データを前記管制センタに送信する
ことを特徴とするソフトウェア更新装置。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE112023004500.3T DE112023004500T5 (de) | 2023-01-12 | 2023-01-12 | Softwareaktualisierungssystem, steuerzentrale und softwareaktualisierungsvorrichtung |
| PCT/JP2023/000617 WO2024150372A1 (ja) | 2023-01-12 | 2023-01-12 | ソフトウェア更新システム、管制センタ、およびソフトウェア更新装置 |
| JP2024569945A JPWO2024150372A1 (ja) | 2023-01-12 | 2023-01-12 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/JP2023/000617 WO2024150372A1 (ja) | 2023-01-12 | 2023-01-12 | ソフトウェア更新システム、管制センタ、およびソフトウェア更新装置 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2024150372A1 true WO2024150372A1 (ja) | 2024-07-18 |
Family
ID=91896556
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2023/000617 Ceased WO2024150372A1 (ja) | 2023-01-12 | 2023-01-12 | ソフトウェア更新システム、管制センタ、およびソフトウェア更新装置 |
Country Status (3)
| Country | Link |
|---|---|
| JP (1) | JPWO2024150372A1 (ja) |
| DE (1) | DE112023004500T5 (ja) |
| WO (1) | WO2024150372A1 (ja) |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2015135552A (ja) * | 2014-01-16 | 2015-07-27 | 株式会社デンソー | 学習システム、車載装置、及び、サーバ |
| WO2017212639A1 (ja) * | 2016-06-10 | 2017-12-14 | パイオニア株式会社 | 情報処理装置、計測装置及び制御方法 |
| JP2018167648A (ja) * | 2017-03-29 | 2018-11-01 | マツダ株式会社 | 車両運転支援システム及び車両運転支援方法 |
| JP2019182093A (ja) * | 2018-04-05 | 2019-10-24 | トヨタ自動車株式会社 | 挙動予測装置 |
| WO2022113772A1 (ja) * | 2020-11-27 | 2022-06-02 | ソニーグループ株式会社 | 情報処理装置、情報処理方法、及び、情報処理システム |
-
2023
- 2023-01-12 WO PCT/JP2023/000617 patent/WO2024150372A1/ja not_active Ceased
- 2023-01-12 JP JP2024569945A patent/JPWO2024150372A1/ja active Pending
- 2023-01-12 DE DE112023004500.3T patent/DE112023004500T5/de active Pending
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2015135552A (ja) * | 2014-01-16 | 2015-07-27 | 株式会社デンソー | 学習システム、車載装置、及び、サーバ |
| WO2017212639A1 (ja) * | 2016-06-10 | 2017-12-14 | パイオニア株式会社 | 情報処理装置、計測装置及び制御方法 |
| JP2018167648A (ja) * | 2017-03-29 | 2018-11-01 | マツダ株式会社 | 車両運転支援システム及び車両運転支援方法 |
| JP2019182093A (ja) * | 2018-04-05 | 2019-10-24 | トヨタ自動車株式会社 | 挙動予測装置 |
| WO2022113772A1 (ja) * | 2020-11-27 | 2022-06-02 | ソニーグループ株式会社 | 情報処理装置、情報処理方法、及び、情報処理システム |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2024150372A1 (ja) | 2024-07-18 |
| DE112023004500T5 (de) | 2025-08-21 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN109747659B (zh) | 车辆驾驶的控制方法和装置 | |
| US12044532B2 (en) | Sensor plausibility using GPS road information | |
| US11269329B2 (en) | Dynamic model with learning based localization correction system | |
| EP3358303B1 (en) | An apparatus and associated methods for use in updating map data | |
| EP3644294B1 (en) | Vehicle information storage method, vehicle travel control method, and vehicle information storage device | |
| US11092442B2 (en) | Host vehicle position estimation device | |
| US20160259814A1 (en) | Map data processing device for vehicle | |
| CN112074885A (zh) | 车道标志定位 | |
| CN113064143A (zh) | 用于具有多LiDAR传感器的自动驾驶车辆的再校准确定系统 | |
| EP4242998B1 (en) | Traffic stream information determination method and apparatus, electronic device and storage medium | |
| KR102611507B1 (ko) | 주행 지원 방법 및 주행 지원 장치 | |
| US20200276984A1 (en) | Server and Vehicle Control System | |
| US20210078588A1 (en) | Autonomous driving monitoring system | |
| CN110888429A (zh) | 车辆导航和控制 | |
| CN116528154B (zh) | 用于界定区域内的车辆驾驶辅助的方法 | |
| US12269507B2 (en) | Distributional expert demonstrations for autonomous driving | |
| CN113885011B (zh) | 自动车辆的基于点云图的光检测测距重新校准系统 | |
| CN110869865B (zh) | 用于运行较高程度自动化的车辆(haf)、尤其高度自动化车辆的方法 | |
| CN110114634B (zh) | 外界识别系统 | |
| CN109313851B (zh) | 用于逆行驾驶员识别的方法、设备和系统 | |
| CN115046547B (zh) | 一种复杂城市环境下的自动驾驶汽车定位系统及方法 | |
| US11983918B2 (en) | Platform for perception system development for automated driving system | |
| CN119968600A (zh) | 无人驾驶车辆的激光雷达与相机的灵活同步 | |
| US20250376193A1 (en) | Processing device, processing method, storage device storing processing program | |
| KR20230109942A (ko) | 자율 주행을 위한 정밀지도 업데이트 시스템 및 이를 이용한 정밀지도 업데이트 방법 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 23915994 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2024569945 Country of ref document: JP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 112023004500 Country of ref document: DE |
|
| WWP | Wipo information: published in national office |
Ref document number: 112023004500 Country of ref document: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 23915994 Country of ref document: EP Kind code of ref document: A1 |