KR20180080529A - Automatic welders for pipes - Google Patents
Automatic welders for pipes Download PDFInfo
- Publication number
- KR20180080529A KR20180080529A KR1020170001332A KR20170001332A KR20180080529A KR 20180080529 A KR20180080529 A KR 20180080529A KR 1020170001332 A KR1020170001332 A KR 1020170001332A KR 20170001332 A KR20170001332 A KR 20170001332A KR 20180080529 A KR20180080529 A KR 20180080529A
- Authority
- KR
- South Korea
- Prior art keywords
- pipe
- welding
- welding apparatus
- moving
- base frame
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images





Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K28/00—Welding or cutting not covered by groups B23K5/00 - B23K26/00
- B23K28/02—Combined welding or cutting procedures or apparatus
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K10/00—Welding or cutting by means of a plasma
- B23K10/02—Plasma welding
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K37/00—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass
- B23K37/04—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass for holding or positioning work
- B23K37/047—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass for holding or positioning work moving work to adjust its position between soldering, welding or cutting steps
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K9/00—Arc welding or cutting
- B23K9/16—Arc welding or cutting making use of shielding gas
- B23K9/167—Arc welding or cutting making use of shielding gas and of a non-consumable electrode
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K9/00—Arc welding or cutting
- B23K9/32—Accessories
- B23K9/325—Devices for supplying or evacuating shielding gas
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K2101/00—Articles made by soldering, welding or cutting
- B23K2101/04—Tubular or hollow articles
- B23K2101/10—Pipe-lines
-
- B23K2201/10—
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Physics & Mathematics (AREA)
- Plasma & Fusion (AREA)
- Optics & Photonics (AREA)
- Butt Welding And Welding Of Specific Article (AREA)
- Arc Welding In General (AREA)
Abstract
본 발명은 파이프의 단관과 단관의 이음 용접을 위한 용접장치를 플라즈마 용접장치와 티그 용접장치로 구성하여 플라즈마 용접장치의 빠른 용접으로 용접시간을 단축시킬 수 있고, 용접부의 기계적 성질이 매우 우수하고 내부식성이 우수한 티그 용접장치를 통해 용접품질을 향상시킬 수 있도록 하기 위한 파이프 자동 용접장치를 제공한다. 본 발명은 파이프의 이음 용접을 위한 용접장치와 파이프를 지지하기 위한 파이프 지지부를 하나의 장치에 구성함으로써 파이프 이음 부분과 용접장치의 용접헤드의 위치 보다 쉽게 일치킬 수 있어 용접 시간을 단축할 수 있고, 효율성을 증대시킬 수 있는 효과가 있다. 또한, 티그 용접장치의 가스포켓을 파이프의 외주면에 대응하여 파이프를 감싸도록 구성함으로써 용접 중 발생하는 공기 침투로 인한 변색 및 산화를 방지하여 용접품질을 향상시킬 수 있는 효과가 있다.The present invention is characterized in that a welding apparatus for joint welding between a single pipe and a single pipe of a pipe is constituted by a plasma welding apparatus and a tig welding apparatus so that the welding time can be shortened by fast welding of the plasma welding apparatus, There is provided an automatic pipe welding apparatus for improving welding quality through a corrosion-resistant tig welding apparatus. The present invention can more easily match the position of the welding head of the welding apparatus with that of the pipe joint by constituting the welding apparatus for joint welding the pipe and the pipe support for supporting the pipe in one apparatus so as to shorten the welding time , The efficiency can be increased. In addition, since the gas pocket of the TIG welding apparatus is configured to surround the pipe in correspondence with the outer circumferential surface of the pipe, discoloration and oxidation due to air infiltration occurring during welding can be prevented, and welding quality can be improved.
Description
본 발명은 파이프 자동 용접장치에 관한 것으로, 좀 더 구체적으로는 파이프의 단관과 단관의 이음 용접을 위한 용접장치를 플라즈마 용접장치와 티그 용접장치로 구성하여 플라즈마 용접장치의 빠른 용접으로 용접시간을 단축시킬 수 있고, 용접부의 기계적 성질이 매우 우수하고 내부식성이 우수한 티그 용접장치를 통해 용접품질을 향상시킬 수 있도록 하기 위한 파이프 자동 용접장치에 관한 것이다.The present invention relates to an automatic pipe welding apparatus, and more particularly, to a welding apparatus for welding a single pipe and a single pipe of a pipe by a plasma welding apparatus and a tig welding apparatus, The present invention relates to an automatic pipe welding apparatus for improving welding quality through a tig welding apparatus having excellent mechanical properties of a welded portion and excellent corrosion resistance.
플라즈마를 이용한 용접은 높은 열원을 사용하여 국부적인 열 영향을 끼침으로 인해, 다른 일반 용접과는 달리 용접속도가 빠르고 열영향부가 좁아 변형과 조직의 성질변화가 적다는 이점이 있다. 그러나 플라즈마의 아크 특성상 토치의 높이에 민감하며, 아크를 안정화시키기 위해서는 토치높이가 일정하게 유지되는 것이 요구된다.Plasma welding is advantageous because it uses a high heat source and has a local heat effect, unlike other general welding, welding speed is fast and the heat affected part is narrow, so that the deformation and the property change of the structure is small. However, due to the nature of the arc of the plasma, it is sensitive to the height of the torch and it is required that the torch height be kept constant to stabilize the arc.
일반적으로 파이프 제조공정에 있어서 플라즈마 용접은 곡면으로 성형된 부재의 길이방향 용접에 많이 적용되고 있다. 그러나 이렇게 제조된 제품의 단관과 단관을 결합하는 원주 용접에 있어서 구경이 적은 튜브나 파이프류의 초층 용접은 티그용접이 적용되고 있으며, 초층을 제외한 나머지 적층은 티그용접을 그대로 사용하여 적층하거나, 개스 메탈 아크 용접법(GMAW) 혹은 플럭스 코어드 아크 용접(FCAW)법을 사용하여 나머지 개선에 대한 용접을 하고 있다. 실제 초층 용접에 사용되는 플라즈마의 용접속도는 티그용접에 비해 약 3배 정도 빠르다.Generally, in the pipe manufacturing process, plasma welding is widely applied to the longitudinal welding of a curved member. However, in the circumferential welding which combines the single pipe and the single pipe of the manufactured product, the ultra-wide welding of tubes or pipes having a small diameter is applied by the use of the teig welding, and the lamination other than the superfine layer is laminated using the tig welding as it is, Welding is done for the rest of the improvement using metal arc welding (GMAW) or flux cored arc welding (FCAW). The welding speed of the plasma used for actual layered welding is about three times faster than that of the tig welding.
이러한 복관 제작공정은 현재 대부분 티그용접을 적용하여 초층 용접에 적용하고 있으며, 나머지 적층용접은 티그용접을 적용할 경우 생산성이 낮고, 별도의 다른 장치에 있는 용접토치로 나머지 적층하는 것은 장치운용이 불편하다. 또한, 플라즈마 용접의 아크 안정화가 대단히 중요하다는 점에서 파이프의 진원도 오차에 따른 토치의 높낮이 조정을 대부분 수동으로 하고 있어서 용접결함 발생이라는 문제점이 있었다.Most of these cuvette manufacturing processes are currently applied to the ultra-wide welding with the use of the tig welding, while the productivity of the remaining lamination welding is low when the tig welding is applied and the remaining lamination with the welding torch in another device is inconvenient to operate the device . In addition, since arc stabilization of the plasma welding is very important, adjustment of the height of the torch according to the roundness error of the pipe is mostly manual, which causes a problem of welding defect.
이와 같은 문제점으로 인해 플라즈마 용접장치와 티그 용접장치를 동시에 구성한 기술이 제안되었는 바, 특허문헌 1의 용접장치는 도 1에서 보는 바와 같이 바퀴를 구비하고 주행레일(100)을 따라 이동가능하게 설치되는 대차(102)와 상기 대차(102)의 상면에 설치되어 프라즈마 및 일반 용접기능을 수행하는 플라즈마 용접기(103)와 일반 용접기(104) 및 상기 플라즈마 용접기(103)와 일반 용접기(104)의 구동 및 장치의 전반적인 제어기능을 수행하는 제어장치반(105); 상기 대차(102)의 상면에 설치되는 컬럼 회전기어(106)와 상기 컬럼 회전기어(106)의 상면에 전단부가 고정 설치되어 90도의 범위내에서 회전가능하게 설치된 컬럼(107); 상기 컬럼(107)의 상단에 일단부가 고정 설치되어 수평의 구조를 하고 있는 붐대(200); 상기 붐대(200)의 일측에 설치된 두개의 헤드로 그 일측은 초층 용접을 위한 플라즈마 용접헤드로, 타측은 초층 위에 적층을 위한 용접헤드로 복합적으로 구성되는 헤드부(300);용접될 파이프 단관(401)을 받쳐주되, 단관(401)을 회전시키면서 일정한 회전영역을 벗어나지 못하도록 상기 주행레일과 평행한 방향으로 설치되는 터닝롤러(402)와 상기 터닝롤러(402)를 구동시키기 위한 터닝롤러 구동모터(403)를 포함하여 이루어진다.As a result of such a problem, a technique has been proposed in which a plasma welding apparatus and a tig welding apparatus are simultaneously configured. In the welding apparatus of Patent Document 1, as shown in FIG. 1, the welding apparatus includes wheels and is installed to be movable along the running rail 100
그러나, 상기의 용접장치는 파이프 단관이 터닝롤러에 의해 회전되어 용접시 외부의 충격 또는 외부 환경에 의해 파이프 단관이 터닝롤러의 상부에서 이탈되는 경우가 발생하여 용접이 진행되지 못하고, 사고가 발생하는 문제점이 있었다. 또한, 용접장치가 설치된 대차와 파이프 단관을 받쳐주는 터닝롤러가 별도로 구성되어 있어 파이프 단관의 이음부와 용접기의 용접헤드의 위치를 일치시키기 위해 작업자가 수작업으로 해야하기 때문에 시간이 오래걸림과 동시에 불편함이 있었다.However, in the above welding apparatus, when the pipe end is rotated by the turning roller, there is a case where the end pipe is detached from the upper part of the turning roller due to external impact or external environment during welding, There was a problem. In addition, since the bogie equipped with the welding device and the turning roller for supporting the pipe end pipe are separately constructed, the worker must manually perform the work to match the joint of the pipe end and the welding head of the welder, There was.
따라서 본 발명은 이와 같은 종래 문제점을 개선하기 위해 제안된 것으로, 파이프의 단관과 단관의 이음 용접을 위한 용접장치를 플라즈마 용접장치와 티그 용접장치로 구성하여 플라즈마 용접장치의 빠른 용접으로 용접시간을 단축시킬 수 있고, 용접부의 기계적 성질이 매우 우수하고 내부식성이 우수한 티그 용접장치를 통해 용접품질을 향상시킬 수 있도록 하기 위한 새로운 형태의 파이프 자동 용접장치를 제공하는 것을 해결하고자 하는 과제로 한다.SUMMARY OF THE INVENTION Accordingly, the present invention has been made in order to solve the above problems, and it is an object of the present invention to provide a plasma welding apparatus and a tig welding apparatus for welding a single pipe and a single pipe, The present invention has been made to solve the above-mentioned problems occurring in the prior art, and it is an object of the present invention to provide a new type automatic pipe welding apparatus for improving welding quality through a tig welding apparatus having excellent mechanical properties and excellent corrosion resistance.
특히, 파이프의 이음 용접을 위한 용접장치와 파이프를 지지하기 위한 파이프 지지부를 하나의 장치에 구성함으로써 파이프 이음 부분과 용접장치의 용접헤드의 위치 보다 쉽게 일치킬 수 있어 용접 시간을 단축할 수 있고, 효율성을 증대시킬 수 있도록 하는 새로운 형태의 파이프 자동 용접장치를 제공하는 것을 해결하고자 하는 다른 과제로 한다.Particularly, since the welding device for joint welding pipes and the pipe supporting part for supporting pipes can be formed in one device, it is possible to more easily match the position of the welding head of the welding device with the pipe joint part, Another object of the present invention is to provide a new type automatic pipe welding apparatus capable of increasing efficiency.
또한, 티그 용접장치의 가스포켓을 파이프의 외주면에 대응하여 파이프를 감싸도록 구성함으로써 용접 중 발생하는 공기 침투로 인한 변색 및 산화를 방지하여 용접품질을 향상시킬 수 있도록 하는 새로운 형태의 파이프 자동 용접장치를 제공하는 것을 해결하고자 하는 또 다른 과제로 한다.In addition, by configuring the gas pocket of the TIG welding device so as to surround the pipe in correspondence with the outer circumferential surface of the pipe, it is possible to prevent discoloration and oxidation due to air infiltration during welding, Which is a problem to be solved.
상술한 목적을 달성하기 위한 본 발명의 특징에 의하면, 내부에 동력발생부(21)가 설치되는 베이스 프레임(20)과; 상기 베이스 프레임(20)의 상부에 설치되고, 상기 베이스 프레임(20)의 동력발생부(21)에 의해 좌우 이동되고, 파이프(100)를 지지하기 위한 파이프 지지부(30)와; 상기 베이스 프레임(20)의 상부 일측에 상하 이동가능하게 설치되는 상하 이동부(41)와; 상기 상하 이동부(41)에 설치되고, 좌우 이동이 가능하게 설치되는 좌우 이동부(42)와; 상기 좌우 이동부(42)에 설치되고, 전후 이동이 가능하게 설치되는 전후 이동부(43)와; 상기 전후 이동부(43)에 설치되고, 상기 파이프를 용접하기 위한 용접장치(50)와; 상기 베이스 프레임(20)의 동력발생부(21), 상하 이동부(41), 좌우 이동부(42), 전후 이동부(43) 및 용접장치(50)를 제어하기 위한 제어부(60)를 포함하는 것을 특징으로 한다.According to an aspect of the present invention for achieving the above-mentioned object, there is provided a power transmission device comprising: a base frame (20) having a power generating portion (21) installed therein; A
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 상기 용접장치(50)는 플라즈마 용접장치(70) 및 티그 용접장치(80)인 것을 특징으로 한다.In the automatic pipe welding apparatus according to the present invention, the
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 상기 용접장치(50)의 플라즈마 용접장치(70)는 상기 전후 이동부(43)의 상부 일측에 위치되고, 와이어가 권취된 와이어 피더(71)와; 상기 전후 이동부(43)의 타측에 결합되는 고정바(72)와; 상기 고정바(72)의 끝단에 회동가능하게 형성되고, 상기 파이프를 용접하기 위한 용접토치(74)를 고정하기 위한 고정구(73)를 포함하여, 상기 고정구(73)에 고정된 상기 용접토치(74)는 수직 또는 수평 방향으로 용접이 가능하도록 형성되는 것을 특징으로 한다.In the pipe automatic welding apparatus according to the present invention, the
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 상기 용접장치(50)의 티그 용접장치(80)는 상기 전후 이동부(43)의 상부 일측에 위치되고, 와이어가 권취된 와이어 피더(81)와; 상기 전후 이동부(43)의 타측에 하부 방향으로 형성되는 고정바(82)와; 상기 고정바(82)의 끝단에 수평 방향으로 형성되는 수평바(83)와; 상기 수평바(83)의 끝단에 형성되고, 상기 파이프를 용접하기 위한 용접토치(86)를 고정하기 위한 고정구(84)와; 상기 파이프를 감싸도록 형성되어 용접시 상기 파이프의 용접부분에 가스를 분사하기 위한 가스포켓(85)을 포함하는 것을 특징으로 한다.In the pipe automatic welding apparatus according to the present invention, the
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 상기 가스포켓(85)은 용접대상이 되는 파이프의 외주면에 배치되고, 상기 파이프를 용접하기 위한 용접토치(86)가 장착되는 본체(851)와; 상기 파이프의 외주면을 감싸도록 상기 본체(851)의 일측에 연결되고, 상기 파이프의 용접부분에 가스를 분사하기 위한 복수 개의 트레일링(852)과; 상기 본체(851)와 트레일링(852), 복수 개의 트레일링(852)을 서로 연결하기 위한 연결부재(853)와; 상기 연결부재(853)와 본체(851), 복수 개의 트레일링(852)을 체결하기 위한 체결부재(854)를 포함하고, 상기 본체(851), 복수 개의 트레일링(852), 연결부재(853), 체결부재(854)는 서로 분리되어 착탈 가능하게 조립되는 구조인 동시에 상기 체결부재(854)의 조임력에 의해 상기 본체(851)와 복수 개의 트레일링(852) 간 고정과 고정해제가 유도되면서 상기 트레일링(852)은 상기 파이프의 직경에 따라 상기 본체(851)에 연결되는 상기 연결부재(853)의 각도가 조절되어 상기 파이프의 외주면을 감싸도록 상기 본체(851)에 연결되는 것을 특징으로 한다.In the automatic pipe welding apparatus according to the present invention, the
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 파이프 지지부(30)는 상기 베이스 프레임(20)의 상부에 이격되어 설치되는 지지대(31)와; 상기 지지대(31) 사이에 설치되고, 상기 동력발생부(21)의 구동으로 회동하는 연결대(32)와; 상기 연결대(32) 상에 설치되고, 상기 파이프의 하부를 지지하기 위한 하부지지롤러(33)와; 일단이 상기 상하 이동부(41)에 고정되고, 상기 파이프의 상부를 눌러 지지하기 위한 상부지지롤러(34)를 포함하여, 상기 파이프의 크기에 따라 상기 하부지지롤러(33)가 상기 연결대(32) 상에서 좌우 이동되어 상기 파이프의 하부를 지지하도록 하는 것을 특징으로 한다.In the pipe automatic welding apparatus according to the present invention, the
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 상기 베이스 프레임(20)의 전면에 상기 파이프(100)를 길이방향으로 이동시켜 상기 용접장치(50)에 의해 상기 파이프(100)가 길이방향으로 용접될 수 있도록 하기 위한 파이프 이동부(90)가 설치되는 것을 특징으로 한다.In the automatic pipe welding apparatus according to the present invention, the
이와 같은 본 발명에 따른 파이프 자동 용접장치에서 상기 파이프 이동부(90)는 바닥에 설치되는 레일(91)을 따라 이동가능하게 설치되는 대차(92)와; 상기 대차(92)의 상부에 상기 파이프 지지부(30)와 대응되는 높이로 형성되어 상기 파이프(100)의 하부를 지지하기 위한 지지부(93)와; 상기 대차(92)의 상부에 구비되고, 상기 대차(92)를 레일(91)을 따라 이동시키기 위한 구동부(94)를 포함하는 것을 특징으로 한다.In the pipe automatic welding apparatus according to the present invention, the
이상과 같이 본 발명에 따른 파이프 자동 용접장치에 의하면, 파이프의 단관과 단관의 이음 용접을 위한 용접장치를 플라즈마 용접장치와 티그 용접장치로 구성하여 플라즈마 용접장치의 빠른 용접으로 용접시간을 단축시킬 수 있고, 용접부의 기계적 성질이 매우 우수하고 내부식성이 우수한 티그 용접장치를 통해 용접품질을 향상시킬 수 있도록 하는 효과가 있다.As described above, according to the automatic pipe welding apparatus of the present invention, the welding apparatus for joint welding between a single pipe and a single pipe of a pipe is constituted by a plasma welding apparatus and a tig welding apparatus, There is an effect that the welding quality can be improved through a tig welding apparatus having excellent mechanical properties of the welded portion and excellent corrosion resistance.
특히, 파이프의 이음 용접을 위한 용접장치와 파이프를 지지하기 위한 파이프 지지부를 하나의 장치에 구성함으로써 파이프 이음 부분과 용접장치의 용접헤드의 위치 보다 쉽게 일치킬 수 있어 용접 시간을 단축할 수 있고, 효율성을 증대시킬 수 있는 효과가 있다.Particularly, since the welding device for joint welding pipes and the pipe supporting part for supporting pipes can be formed in one device, it is possible to more easily match the position of the welding head of the welding device with the pipe joint part, There is an effect that the efficiency can be increased.
또한, 티그 용접장치의 가스포켓을 파이프의 외주면에 대응하여 파이프를 감싸도록 구성함으로써 용접 중 발생하는 공기 침투로 인한 변색 및 산화를 방지하여 용접품질을 향상시킬 수 있는 효과가 있다.In addition, since the gas pocket of the TIG welding apparatus is configured to surround the pipe in correspondence with the outer circumferential surface of the pipe, discoloration and oxidation due to air infiltration occurring during welding can be prevented, and welding quality can be improved.
도 1은 종래 기술을 설명하기 위한 도면,
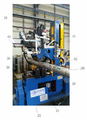
도 2는 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치를 보여주는 사진,
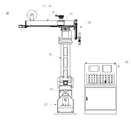
도 3은 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치의 정면도,
도 4는 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치의 측면도,
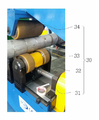
도 5는 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치에서 파이프 지지부를 보여주는 도면,
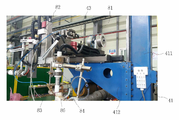
도 6은 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치에서 용접장치를 보여주는 도면,
도 7은 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치에서 티그 용접장치를 보여주는 도면,
도 8은 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치에서 티그 용접장치의 가스포켓을 보여주는 도면,
도 9는 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치에서 파이프의 길이방향 용접을 위한 파이프 이동부를 보여주는 도면이다.1 is a view for explaining a conventional technique,
FIG. 2 is a photograph showing an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
3 is a front view of an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
4 is a side view of an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
5 is a view showing a pipe support in an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
6 is a view showing a welding apparatus in an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
7 is a view showing a tig welding apparatus in an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
8 is a view showing a gas pocket of a tig welding apparatus in an automatic pipe welding apparatus according to a preferred embodiment of the present invention,
9 is a view showing a pipe moving part for longitudinal welding of a pipe in an automatic pipe welding apparatus according to a preferred embodiment of the present invention.
이하, 본 발명의 바람직한 실시예를 첨부된 도면에 의거하여 상세히 설명하며, 도 2 내지 도 9에 있어서 동일한 기능을 수행하는 구성 요소에 대해서는 동일한 참조 번호를 병기한다. 한편, 도면의 도시 및 상세한 설명에 있어서 본 발명의 기술적 특징과 직접적으로 연관되지 않는 요소의 구체적인 기술적 구성 및 작용에 대한 상세한 설명 및 도시는 생략하고, 본 발명과 관련되는 기술적 구성만을 간략하게 도시하거나 설명하였다.DETAILED DESCRIPTION OF THE PREFERRED EMBODIMENTS Hereinafter, preferred embodiments of the present invention will be described in detail with reference to the accompanying drawings. In FIGS. 2 to 9, the same reference numerals are assigned to components performing the same function. In the drawings and the detailed description, detailed description of specific elements and functions of elements not directly related to the technical features of the present invention will be omitted. .
도 2 내지 도 8을 참고하면, 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치(10)는 베이스 프레임(20), 파이프 지지부(30), 상하 이동부(41), 좌우 이동부(42), 전후 이동부(43), 용접장치(50) 및 제어부(60)를 포함하여 이루어진다.2 to 8, an automatic
베이스 프레임(20)은 바닥에 안치되고, 후술하는 구성요소들이 고정, 결합되는 것으로, 박스형상으로 이루어져 내부에 동력발생부(21)가 설치되어 진다. 여기서, 동력발생부(21)는 모터로 이루어지는 것이 바람직하다.The
한편, 베이스 프레임(20)은 내부에 설치된 동력발생부(21)의 파손, 고장 등으로 인해 보수 및 교체를 용아하게 하기 위해 전면에 도어(22)가 설치되어 진다.On the other hand, the
파이프 지지부(30)는 베이스 프레임(20)의 상부에 설치되고, 파이프가 안치되어 지지되는 것으로, 베이스 프레임(20)의 동력발생부(21)의 동작으로 좌우 이동되어 상부에 파이프가 지지되도록 한다.The
파이프 지지부(30)는 베이스 프레임(20)의 상부에 이격되어 설치되는 지지대(31)와, 지지대(31) 사이에 설치되고, 동력발생부(21)의 구동으로 회동하는 연결대(32)와, 연결대(32) 상에 설치되고, 파이프의 하부를 지지하기 위한 하부지지롤러(33)와, 일단이 상하 이동부(41)에 고정되고, 파이프의 상부를 눌러 지지하기 위한 상부지지롤러(34)를 포함하여 이루어진다.The
한편, 하부지지롤러(33)는 파이프의 하부를 지지하기 위해 2개로 구성되는데, 동력발생부(21)의 구동에 의해 연결대(32) 상에서 이동시 2개의 하부지지롤러(33)는 서로 반대되는 방향으로 이동되도록 구성된다.The
이와 같은 구성을 갖는 파이프 지지구(30)는 동력발생부(21)의 구동에 의해 연결대(32)가 회동하여 파이프의 크기에 대응하여 하부지지롤러(33)를 좌우로 이동시켜 파이프의 하부를 지지하도록 한다. 그리고, 상부지지롤러(34)는 하부지지롤러(33)의 상부에 안치된 파이프의 상부를 눌러 외부의 충격으로부터 이탈을 방지하고, 안정적으로 하부지지롤러(33)에 지지되도록 한다.The
상하 이동부(41)는 베이스 프레임(20)의 상부 일측에 설치되어 용접장치(50)를 이동시키기 위한 것으로, 베이스 프레임(20)의 상부 일측에 수직 방향으로 설치되어 수직대(411)와, 수직대(411) 상에서 상하 이동가능하게 결합되는 이동대(412)와, 수직대(411)의 측면에 설치되어 이동대(412)를 상하 방향으로 이동시키기 위한 구동부(413)를 포함하여 이루어진다. 이때, 이동대(412)의 하부에는 파이프 지지부(30)의 상부지지롤러(34)가 결합되고, 상부에는 후술하는 좌우 이동부(42)가 결합되어 진다.The vertical moving
상하 이동부(41)의 이동대(412) 상부에 결합되는 좌우 이동부(42)는 전후 이동이 가능하게 설치되고, 이 좌우 이동부(42)의 상부에 좌우 이동부(42)와 직교되는 방향으로 전후 이동이 가능하도록 전후 이동부(43)가 설치되어 진다.The left and right moving
한편, 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치(10)에서 상하 이동부(41), 좌우 이동부(42), 전후 이동부(43)는 구동부의 구동으로 상하, 좌우, 전후 이동되는 것으로 구동부는 통상의 모터로 구성될 수 있고, 모터와 체인, 스크류, 컨베이어 등 다양한 방법으로 상하, 좌우, 전후 이동되도록 할 수 있을 것이다.In the automatic
용접장치(50)는 전후 이동부에 설치되고, 파이프 지지부(30)에 지지된 파이프의 이음부를 용접하기 위한 것으로, 플라즈마 용접장치(70)와 티그 용접장치(80)로 이루어진다.The
플라즈마 용접장치(70)는 전후 이동부(43)의 상부 일측에 위치되고, 와이어가 권취된 와이어 피더(71)와, 전후 이동부(43)의 타측에 결합되는 고정바(72)와, 고정바(72)의 끝단에 회동가능하게 형성되고, 파이프를 용접하기 위한 용접토치(74)를 고정하기 위한 고정구(73)를 포함하여 이루어진다. 이때, 고정구(73)에 고정된 용접토치(74)는 수직 또는 수평 방향으로 용접이 가능하도록 형성되어 진다.The
한편, 플라즈마 용접장치(70)에서 고정바(72)는 전후 이동부에 결합되되, 상하 방향으로 이동가능하게 결합되어 진다. 이는 파이프 지지부(30)에 의해 지지된 파이프의 이음부를 용접시 상하 이동부(41)에 의해 상하 이동이 되지만 파이프 이음부와의 미세 간격을 조절하기 위해 고정바(72)는 상하 방향으로 이동되도록 형성되어 진다.On the other hand, in the
티그 용접장치(80)는 전후 이동부(43)의 상부 일측에 위치되고, 와이어가 권취된 와이어 피더(81)와, 전후 이동부(43)의 타측에 하부 방향으로 형성되는 고정바(82)와, 고정바(82)의 끝단에 수평 방향으로 형성되는 수평바(83)와, 수평바(83)의 끝단에 형성되고, 파이프를 용접하기 위한 용접토치(86)를 고정하기 위한 고정구(84)와, 파이프를 감싸도록 형성되어 용접시 파이프의 용접부분에 가스를 분사하기 위한 가스포켓(85)을 포함하여 이루어진다.The
한편, 티그 용접장치(80)에서 고정바(82)는 전후 이동부(43)에 결합되되, 상하 방향으로 이동가능하게 결합되어 진다. 이는 파이프 지지부(30)에 의해 지지된 파이프의 이음부를 용접시 상하 이동부(41)에 의해 상하 이동이 되지만 파이프 이음부와의 미세 간격을 조절하기 위해 고정바(82)는 상하 방향으로 이동되도록 형성되어 진다.On the other hand, in the
그리고, 가스포켓(85)은 용접대상이 되는 파이프의 외주면에 배치되고, 파이프를 용접하기 위한 용접토치(86)가 장착되는 본체(851)와, 파이프의 외주면을 감싸도록 본체(851)의 일측에 연결되고, 파이프의 용접부분에 가스를 분사하기 위한 복수 개의 트레일링(852)과, 본체(851)와 트레일링(852), 복수 개의 트레일링(852)을 서로 연결하기 위한 연결부재(853)와, 연결부재(853)와 본체(851), 복수 개의 트레일링(852)을 체결하기 위한 체결부재(854)를 포함하여 이루어진다. 이때, 본체(851), 복수 개의 트레일링(852), 연결부재(853), 체결부재(854)는 서로 분리되어 착탈 가능하게 조립되는 구조인 동시에 체결부재(854)의 조임력에 의해 본체(851)와 복수 개의 트레일링(852) 간 고정과 고정해제가 유도되면서 트레일링(852)은 파이프의 직경에 따라 본체(851)에 연결되는 연결부재(853)의 각도가 조절되어 파이프의 외주면을 감싸도록 본체(851)에 연결되어 진다.The
한편, 본체(851)에 복수 개의 트레일링(852)를 체결하기 위한 체결부재(854)는 볼트(8541)와 너트(미도시)로 구성되고, 너트는 트레일링(852)의 내부에 고정 결합되어 진다.The
본체(851)는 용접토치(86)가 장착되도록 장착홀(8512)이 형성되고, 장착홀(8512)은 용접토치(86)의 크기에 따라 조절될 수 있도록 형성될 수 있을 것이다.The
한편, 본체(851)와 트레일링(852)은 용접시 파이프 이음부에 가스를 분사하기 위한 가스노즐 삽입공(855)이 형성되어 진다.On the other hand, the
제어부(60)는 베이스 프레임(20)의 동력발생부(21), 상하 이동부(41), 좌우 이동부(42), 전후 이동부(43) 및 용접장치(50)를 제어하기 위한 것으로, 파이프 자동 용접장치(10)의 일측에 별도로 구성되어 진다.The
이와 같은 제어부(60)는 수동 또는 자동으로 설정이 가능하도록 구성되어 구성요소들을 제어할 수 있을 것이다.The
이상과 같이 본 발명에 따른 파이프 자동 용접장치에 의하면, 파이프의 단관과 단관의 이음 용접을 위한 용접장치를 플라즈마 용접장치와 티그 용접장치로 구성하여 플라즈마 용접장치의 빠른 용접으로 용접시간을 단축시킬 수 있고, 용접부의 기계적 성질이 매우 우수하고 내부식성이 우수한 티그 용접장치를 통해 용접품질을 향상시킬 수 있도록 하는 효과가 있다.As described above, according to the automatic pipe welding apparatus of the present invention, the welding apparatus for joint welding between a single pipe and a single pipe of a pipe is constituted by a plasma welding apparatus and a tig welding apparatus, There is an effect that the welding quality can be improved through a tig welding apparatus having excellent mechanical properties of the welded portion and excellent corrosion resistance.
특히, 파이프의 이음 용접을 위한 용접장치와 파이프를 지지하기 위한 파이프 지지부를 하나의 장치에 구성함으로써 파이프 이음 부분과 용접장치의 용접헤드의 위치 보다 쉽게 일치킬 수 있어 용접 시간을 단축할 수 있고, 효율성을 증대시킬 수 있는 효과가 있다.Particularly, since the welding device for joint welding pipes and the pipe supporting part for supporting pipes can be formed in one device, it is possible to more easily match the position of the welding head of the welding device with the pipe joint part, There is an effect that the efficiency can be increased.
또한, 티그 용접장치의 가스포켓을 파이프의 외주면에 대응하여 파이프를 감싸도록 구성함으로써 용접 중 발생하는 공기 침투로 인한 변색 및 산화를 방지하여 용접품질을 향상시킬 수 있는 효과가 있다.In addition, since the gas pocket of the TIG welding apparatus is configured to surround the pipe in correspondence with the outer circumferential surface of the pipe, discoloration and oxidation due to air infiltration occurring during welding can be prevented, and welding quality can be improved.
도 9는 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치에서 파이프의 길이방향 용접을 위한 파이프 이동부를 보여주는 도면이다.9 is a view showing a pipe moving part for longitudinal welding of a pipe in an automatic pipe welding apparatus according to a preferred embodiment of the present invention.
도 9를 참조하면, 본 발명에 따른 파이프 자동 용접장치(10)는 파이프(100)의 길이방향 용접을 위해 파이프 이동부(90)가 베이스 프레임(20)의 전면에 설치된다.9, the pipe
파이프 이동부(90)는 베이스 프레임(20)의 전면에 파이프(100)를 길이방향으로 이동시켜 용접장치(50)에 의해 파이프(100)가 길이방향으로 용접될 수 있도록 하기 위한 것으로, 파이프 이동부(90)는 바닥에 설치되는 레일(91)을 따라 이동가능하게 설치되는 대차(92)와, 대차(92)의 상부에 파이프 지지부(30)와 대응되는 높이로 형성되어 파이프(100)의 하부를 지지하기 위한 지지부(93)와, 대차(92)의 상부에 구비되고, 대차(92)를 레일(91)을 따라 이동시키기 위한 구동부(94)를 포함하여 이루어진다. 이때, 구동부(94)는 바람직하게는 모터로 구성되어 진다.The
이와 같이 파이프 이동부(90)를 설치함으로써 파이프(100)를 자동 용접함에 있어 파이프의 단관과 단관의 이음 용접을 할 수 있음은 물론이고, 길이방향으로도 용접이 가능하도록 하는 효과가 있다.By installing the
상술한 바와 같은, 본 발명의 바람직한 실시예에 따른 파이프 자동 용접장치를 상기한 설명 및 도면에 따라 도시하였지만, 이는 예를 들어 설명한 것에 불과하며 본 발명의 기술적 사상을 벗어나지 않는 범위 내에서 다양한 변화 및 변경이 가능하다는 것을 이 분야의 통상적인 기술자들은 잘 이해할 수 있을 것이다.While the present invention has been particularly shown and described with reference to exemplary embodiments thereof, it is to be understood that the invention is not limited to the disclosed exemplary embodiments, but, on the contrary, It will be appreciated by those of ordinary skill in the art that changes are possible.
10 : 파이프 자동 용접장치
20 : 베이스 프레임
21 : 동력발생부
30 : 파이프 지지부
31 : 지지대
32 : 연결대
33 : 하부지지롤러
34 : 상부지지롤러
41 : 상하 이동부
42 : 좌우 이동부
43 : 전후 이동부
50 : 용접장치
60 : 제어부
70 : 플라즈마 용접장치
71 : 와이어 피더
72 : 고정바
73 : 고정구
74 : 용접토치
80 : 티그 용접장치
81 : 와이어 피더
82 : 고정바
83 : 수평바
84 : 고정구
85 : 가스포켓
86 : 용접토치
90 : 파이프 이동부
91 : 레일
92 : 대차
93 : 지지부
94 : 구동부10: Automatic pipe welding machine
20: base frame 21: power generating unit
30: pipe support part 31: support part
32: linkage 33: lower support roller
34: upper support roller 41: upper and lower movable part
42: a left-right moving part 43:
50: welding apparatus 60:
70: Plasma welding device 71: Wire feeder
72: fastening bar 73: fastener
74: welding torch 80:
81: wire feeder 82: fixed bar
83: Horizontal bar 84: Fixture
85: gas pocket 86: welding torch
90: pipe moving part 91: rail
92: carriage 93: support
94:
Claims (8)
상기 베이스 프레임(20)의 상부에 설치되고, 상기 베이스 프레임(20)의 동력발생부(21)에 의해 좌우 이동되고, 파이프(100)를 지지하기 위한 파이프 지지부(30)와;
상기 베이스 프레임(20)의 상부 일측에 상하 이동가능하게 설치되는 상하 이동부(41)와;
상기 상하 이동부(41)에 설치되고, 좌우 이동이 가능하게 설치되는 좌우 이동부(42)와;
상기 좌우 이동부(42)에 설치되고, 전후 이동이 가능하게 설치되는 전후 이동부(43)와;
상기 전후 이동부(43)에 설치되고, 상기 파이프를 용접하기 위한 용접장치(50)와;
상기 베이스 프레임(20)의 동력발생부(21), 상하 이동부(41), 좌우 이동부(42), 전후 이동부(43) 및 용접장치(50)를 제어하기 위한 제어부(60)를 포함하는 것을 특징으로 하는 파이프 자동 용접장치.
A base frame 20 in which a power generating unit 21 is installed;
A pipe supporting part 30 installed on the base frame 20 and moved left and right by the power generating part 21 of the base frame 20 to support the pipe 100;
A vertically moving part 41 vertically movable on one side of the base frame 20;
A left and right moving part (42) provided on the up and down moving part (41) and provided so as to be movable left and right;
A back-and-forth moving unit 43 installed in the left-right moving unit 42 and capable of moving back and forth;
A welding device (50) installed at the front and rear moving part (43) for welding the pipe;
And a control unit 60 for controlling the power generating unit 21, the up and down moving unit 41, the left and right moving unit 42, the back and forth moving unit 43 and the welding apparatus 50 of the base frame 20 Wherein the pipe is welded.
상기 용접장치(50)는 플라즈마 용접장치(70) 및 티그 용접장치(80)인 것을 특징으로 하는 파이프 자동 용접장치.
The method according to claim 1,
Characterized in that the welding device (50) is a plasma welding device (70) and a teig welding device (80).
상기 용접장치(50)의 플라즈마 용접장치(70)는 상기 전후 이동부(43)의 상부 일측에 위치되고, 와이어가 권취된 와이어 피더(71)와;
상기 전후 이동부(43)의 타측에 결합되는 고정바(72)와;
상기 고정바(72)의 끝단에 회동가능하게 형성되고, 상기 파이프를 용접하기 위한 용접토치(74)를 고정하기 위한 고정구(73)를 포함하여,
상기 고정구(73)에 고정된 상기 용접토치(74)는 수직 또는 수평 방향으로 용접이 가능하도록 형성되는 것을 특징으로 하는 파이프 자동 용접장치.
3. The method of claim 2,
The plasma welding apparatus 70 of the welding apparatus 50 includes a wire feeder 71 positioned at one side of the upper side of the back and forth moving unit 43 and wound with a wire;
A fixing bar (72) coupled to the other side of the back and forth moving part (43);
And a fixture (73) rotatably formed at an end of the fixing bar (72) for fixing the welding torch (74) for welding the pipe,
Wherein the welding torch (74) fixed to the fixture (73) is formed to be vertically or horizontally weldable.
상기 용접장치(50)의 티그 용접장치(80)는 상기 전후 이동부(43)의 상부 일측에 위치되고, 와이어가 권취된 와이어 피더(81)와;
상기 전후 이동부(43)의 타측에 하부 방향으로 형성되는 고정바(82)와;
상기 고정바(82)의 끝단에 수평 방향으로 형성되는 수평바(83)와;
상기 수평바(83)의 끝단에 형성되고, 상기 파이프를 용접하기 위한 용접토치(86)를 고정하기 위한 고정구(84)와;
상기 파이프를 감싸도록 형성되어 용접시 상기 파이프의 용접부분에 가스를 분사하기 위한 가스포켓(85)을 포함하는 것을 특징으로 하는 파이프 자동 용접장치.
3. The method of claim 2,
The tig welding apparatus 80 of the welding apparatus 50 includes a wire feeder 81 positioned at one side of the upper side of the back and forth moving unit 43 and wound with a wire;
A fixing bar 82 formed on the other side of the back and forth moving part 43 in a downward direction;
A horizontal bar 83 formed at an end of the fixing bar 82 in a horizontal direction;
A fixture 84 formed at an end of the horizontal bar 83 for fixing a welding torch 86 for welding the pipe;
And a gas pocket (85) formed to surround the pipe and configured to inject gas to the welded portion of the pipe during welding.
상기 가스포켓(85)은 용접대상이 되는 파이프의 외주면에 배치되고, 상기 파이프를 용접하기 위한 용접토치(86)가 장착되는 본체(851)와;
상기 파이프의 외주면을 감싸도록 상기 본체(851)의 일측에 연결되고, 상기 파이프의 용접부분에 가스를 분사하기 위한 복수 개의 트레일링(852)과;
상기 본체(851)와 트레일링(852), 복수 개의 트레일링(852)을 서로 연결하기 위한 연결부재(853)와;
상기 연결부재(853)와 본체(851), 복수 개의 트레일링(852)을 체결하기 위한 체결부재(854)를 포함하고,
상기 본체(851), 복수 개의 트레일링(852), 연결부재(853), 체결부재(854)는 서로 분리되어 착탈 가능하게 조립되는 구조인 동시에 상기 체결부재(854)의 조임력에 의해 상기 본체(851)와 복수 개의 트레일링(852) 간 고정과 고정해제가 유도되면서 상기 트레일링(852)은 상기 파이프의 직경에 따라 상기 본체(851)에 연결되는 상기 연결부재(853)의 각도가 조절되어 상기 파이프의 외주면을 감싸도록 상기 본체(851)에 연결되는 것을 특징으로 하는 파이프 자동 용접장치.
5. The method of claim 4,
The gas pocket (85) is disposed on an outer peripheral surface of a pipe to be welded, and includes a main body (851) on which a welding torch (86) for welding the pipe is mounted;
A plurality of trailing rings 852 connected to one side of the main body 851 to surround the outer circumferential surface of the pipe, for spraying gas to the welded portion of the pipe;
A connecting member 853 for connecting the main body 851 with the trailing ring 852 and the plurality of trailing rings 852;
A main body 851 and a fastening member 854 for fastening the plurality of trailing rings 852,
The main body 851, the plurality of trailing rings 852, the connecting member 853 and the fastening member 854 are detachably assembled and detachably assembled to each other by the tightening force of the fastening member 854, The angle of the connecting member 853 connected to the main body 851 is adjusted according to the diameter of the pipe while the trailing ring 852 is fixed and unlocked between the plurality of trailing rings 851 and 851 and the plurality of trailing rings 852, Is connected to the main body (851) so as to surround the outer circumferential surface of the pipe.
파이프 지지부(30)는 상기 베이스 프레임(20)의 상부에 이격되어 설치되는 지지대(31)와;
상기 지지대(31) 사이에 설치되고, 상기 동력발생부(21)의 구동으로 회동하는 연결대(32)와;
상기 연결대(32) 상에 설치되고, 상기 파이프의 하부를 지지하기 위한 하부지지롤러(33)와;
일단이 상기 상하 이동부(41)에 고정되고, 상기 파이프의 상부를 눌러 지지하기 위한 상부지지롤러(34)를 포함하여,
상기 파이프의 크기에 따라 상기 하부지지롤러(33)가 상기 연결대(32) 상에서 좌우 이동되어 상기 파이프의 하부를 지지하도록 하는 것을 특징으로 하는 파이프 자동 용접장치.
The method according to claim 1,
The pipe support part (30) includes a support base (31) spaced apart from the upper part of the base frame (20);
A linkage (32) installed between the supports (31) and rotating by driving the power generating unit (21);
A lower support roller (33) installed on the linkage (32) for supporting a lower portion of the pipe;
And an upper support roller (34), one end of which is fixed to the up and down moving part (41), for pressing and supporting the upper part of the pipe,
Wherein the lower support roller (33) is moved left and right on the linkage (32) to support the lower portion of the pipe according to the size of the pipe.
상기 베이스 프레임(20)의 전면에 상기 파이프(100)를 길이방향으로 이동시켜 상기 용접장치(50)에 의해 상기 파이프(100)가 길이방향으로 용접될 수 있도록 하기 위한 파이프 이동부(90)가 설치되는 것을 특징으로 하는 파이프 자동 용접장치.
The method according to claim 1,
A pipe moving part 90 for moving the pipe 100 in the longitudinal direction on the front surface of the base frame 20 so that the pipe 100 can be welded in the longitudinal direction by the welding device 50 Wherein the pipe is mounted on the pipe.
상기 파이프 이동부(90)는 바닥에 설치되는 레일(91)을 따라 이동가능하게 설치되는 대차(92)와;
상기 대차(92)의 상부에 상기 파이프 지지부(30)와 대응되는 높이로 형성되어 상기 파이프(100)의 하부를 지지하기 위한 지지부(93)와;
상기 대차(92)의 상부에 구비되고, 상기 대차(92)를 레일(91)을 따라 이동시키기 위한 구동부(94)를 포함하는 것을 특징으로 하는 파이프 자동 용접장치.8. The method of claim 7,
The pipe moving part 90 includes a carriage 92 movably installed along a rail 91 installed on the floor;
A supporting portion 93 formed at the upper portion of the bogie 92 and corresponding to the pipe supporting portion 30 to support the lower portion of the pipe 100;
And a drive unit (94) provided on the bogie (92) for moving the bogie (92) along the rail (91).
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020170001332A KR20180080529A (en) | 2017-01-04 | 2017-01-04 | Automatic welders for pipes |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020170001332A KR20180080529A (en) | 2017-01-04 | 2017-01-04 | Automatic welders for pipes |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| KR20180080529A true KR20180080529A (en) | 2018-07-12 |
Family
ID=62919965
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020170001332A Ceased KR20180080529A (en) | 2017-01-04 | 2017-01-04 | Automatic welders for pipes |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR20180080529A (en) |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102075319B1 (en) * | 2019-11-28 | 2020-02-07 | 최동규 | Pointing part formation method of drawing pipe including the automatic welding step and plasma hole formation step and apparatus thereof |
| CN112139690A (en) * | 2020-09-22 | 2020-12-29 | 重庆欣雨压力容器制造有限责任公司 | Girth welding method adopting P + T and ceramic pad |
| KR102239420B1 (en) * | 2020-04-28 | 2021-04-13 | (주)성일에스아이엠 | Plasma cutting device |
| KR102630538B1 (en) * | 2023-06-16 | 2024-01-30 | 고현호 | automatic welding system |
| PL443883A1 (en) * | 2023-02-24 | 2024-08-26 | Ewikor Construction Spółka Z Ograniczoną Odpowiedzialnością | Method of butt welding of pipes, device for butt welding of pipes and gas mixture used for butt welding of pipes |
| CN119175434A (en) * | 2024-01-30 | 2024-12-24 | 浙江奥桑机械设备有限公司 | Intelligent arc welding workstation based on laser vision and working method thereof |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH07100650A (en) * | 1993-10-06 | 1995-04-18 | Matsumoto Kikai Kk | After shielding device |
| KR20030058889A (en) * | 2002-01-02 | 2003-07-07 | 정중근 | Autometic pipe welding system |
| KR100747792B1 (en) * | 2006-03-17 | 2007-08-08 | 정동옥 | Welding object support device |
| KR101067998B1 (en) * | 2006-06-30 | 2011-09-26 | 현대중공업 주식회사 | Plasma Automatic Welding Device for Pipe Circumferential Welding |
| KR20120040939A (en) * | 2010-10-20 | 2012-04-30 | 삼성중공업 주식회사 | Welding apparatus |
-
2017
- 2017-01-04 KR KR1020170001332A patent/KR20180080529A/en not_active Ceased
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH07100650A (en) * | 1993-10-06 | 1995-04-18 | Matsumoto Kikai Kk | After shielding device |
| KR20030058889A (en) * | 2002-01-02 | 2003-07-07 | 정중근 | Autometic pipe welding system |
| KR100747792B1 (en) * | 2006-03-17 | 2007-08-08 | 정동옥 | Welding object support device |
| KR101067998B1 (en) * | 2006-06-30 | 2011-09-26 | 현대중공업 주식회사 | Plasma Automatic Welding Device for Pipe Circumferential Welding |
| KR20120040939A (en) * | 2010-10-20 | 2012-04-30 | 삼성중공업 주식회사 | Welding apparatus |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102075319B1 (en) * | 2019-11-28 | 2020-02-07 | 최동규 | Pointing part formation method of drawing pipe including the automatic welding step and plasma hole formation step and apparatus thereof |
| KR102239420B1 (en) * | 2020-04-28 | 2021-04-13 | (주)성일에스아이엠 | Plasma cutting device |
| CN112139690A (en) * | 2020-09-22 | 2020-12-29 | 重庆欣雨压力容器制造有限责任公司 | Girth welding method adopting P + T and ceramic pad |
| PL443883A1 (en) * | 2023-02-24 | 2024-08-26 | Ewikor Construction Spółka Z Ograniczoną Odpowiedzialnością | Method of butt welding of pipes, device for butt welding of pipes and gas mixture used for butt welding of pipes |
| KR102630538B1 (en) * | 2023-06-16 | 2024-01-30 | 고현호 | automatic welding system |
| CN119175434A (en) * | 2024-01-30 | 2024-12-24 | 浙江奥桑机械设备有限公司 | Intelligent arc welding workstation based on laser vision and working method thereof |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR101067998B1 (en) | Plasma Automatic Welding Device for Pipe Circumferential Welding | |
| KR101344343B1 (en) | automatic welding system | |
| KR102378732B1 (en) | Pipe Welding System | |
| KR102307068B1 (en) | Automatic welding device with easy angle adjustment | |
| KR101218790B1 (en) | a manipulator of auto welding in pipe | |
| WO2018041236A1 (en) | Welding apparatus and method | |
| CN201140316Y (en) | Apparatus for symmetrical fillet welding | |
| US5099098A (en) | Welding apparatus and method for welding a joint between abutting circular workpieces | |
| KR101614257B1 (en) | Apparatus for pipe butt submerged arc welding | |
| CN209035666U (en) | An automatic welding device for the inner clapboard of a circular tube | |
| KR102886494B1 (en) | Robotic system capable of automatically performing root pass welding on short-length pipes | |
| JP2010137267A (en) | Horizontal type automatic welding equipment for workpiece and workpiece welding method using the same | |
| KR101418933B1 (en) | Automatic Welding Apparatus | |
| KR101334671B1 (en) | Horizontal direction welding submerged arc welding system of rail drive method | |
| KR101925186B1 (en) | Apparatus for steel plate butt submerged arc welding | |
| JP2006051531A (en) | Horizontal-type automatic welding equipment | |
| KR20130005530A (en) | Electro gas welding device of pipes | |
| US6727465B1 (en) | Apparatus for overlay welding of a tube exterior | |
| CN118081096B (en) | External shaft integrated laser arc composite welding head and welding process | |
| KR20140001527U (en) | Welding assistive devices | |
| KR20130051641A (en) | Auto-welding robot with 6 driving axis for angle overlap piece | |
| KR102147720B1 (en) | Replace welding device by replacing MIG and the TIG welding torch with the movement through rail and replace of inactive gas line | |
| KR101572145B1 (en) | Automatic Welding Robot for Submerged Arc welding and welding mathod of the same | |
| KR100556026B1 (en) | Automatic welding device for fabrication of substructure legs of offshore platform | |
| CN212217409U (en) | Auxiliary arc striking and extinguishing device for automatic submerged arc welding |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A201 | Request for examination | ||
| PA0109 | Patent application |
St.27 status event code: A-0-1-A10-A12-nap-PA0109 |
|
| PA0201 | Request for examination |
St.27 status event code: A-1-2-D10-D11-exm-PA0201 |
|
| E14-X000 | Pre-grant third party observation filed |
St.27 status event code: A-2-3-E10-E14-opp-X000 |
|
| D13-X000 | Search requested |
St.27 status event code: A-1-2-D10-D13-srh-X000 |
|
| D14-X000 | Search report completed |
St.27 status event code: A-1-2-D10-D14-srh-X000 |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-3-3-R10-R18-oth-X000 |
|
| PG1501 | Laying open of application |
St.27 status event code: A-1-1-Q10-Q12-nap-PG1501 |
|
| N231 | Notification of change of applicant | ||
| PN2301 | Change of applicant |
St.27 status event code: A-3-3-R10-R13-asn-PN2301 St.27 status event code: A-3-3-R10-R11-asn-PN2301 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| AMND | Amendment | ||
| E13-X000 | Pre-grant limitation requested |
St.27 status event code: A-2-3-E10-E13-lim-X000 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| E601 | Decision to refuse application | ||
| PE0601 | Decision on rejection of patent |
St.27 status event code: N-2-6-B10-B15-exm-PE0601 |
|
| AMND | Amendment | ||
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| PX0901 | Re-examination |
St.27 status event code: A-2-3-E10-E12-rex-PX0901 |
|
| PX0601 | Decision of rejection after re-examination |
St.27 status event code: N-2-6-B10-B17-rex-PX0601 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-3-3-R10-R18-oth-X000 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-3-3-R10-R18-oth-X000 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-3-3-R10-R18-oth-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-2-2-P10-P22-nap-X000 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-3-3-R10-R18-oth-X000 |
|
| R18 | Changes to party contact information recorded |
Free format text: ST27 STATUS EVENT CODE: A-3-3-R10-R18-OTH-X000 (AS PROVIDED BY THE NATIONAL OFFICE) |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-3-3-R10-R18-oth-X000 |