KR20150098508A - Automatic guided vehicle - Google Patents
Automatic guided vehicle Download PDFInfo
- Publication number
- KR20150098508A KR20150098508A KR1020140019883A KR20140019883A KR20150098508A KR 20150098508 A KR20150098508 A KR 20150098508A KR 1020140019883 A KR1020140019883 A KR 1020140019883A KR 20140019883 A KR20140019883 A KR 20140019883A KR 20150098508 A KR20150098508 A KR 20150098508A
- Authority
- KR
- South Korea
- Prior art keywords
- unit
- moving
- line
- body frame
- ground
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
- 238000004891 communication Methods 0.000 claims description 4
- 238000000034 method Methods 0.000 claims description 4
- 238000005516 engineering process Methods 0.000 description 2
- 238000009825 accumulation Methods 0.000 description 1
- 238000013459 approach Methods 0.000 description 1
- 238000004804 winding Methods 0.000 description 1
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/063—Automatically guided
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/0755—Position control; Position detectors
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/07581—Remote controls
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/20—Means for actuating or controlling masts, platforms, or forks
Landscapes
- Engineering & Computer Science (AREA)
- Transportation (AREA)
- Structural Engineering (AREA)
- Civil Engineering (AREA)
- Life Sciences & Earth Sciences (AREA)
- Geology (AREA)
- Mechanical Engineering (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Forklifts And Lifting Vehicles (AREA)
Abstract
본 발명은 무인 자동 운반장치에 관한 것으로, 보다 상세하게는 운반장치를 운전하거나 조작하는 운전자 없이 이동 경로를 안내하는 지면의 라인을 따라 지정된 장소로 물건을 자동으로 운반할 수 있게 하는 무인 자동 운반장치에 관한 것이다.
본 발명에 따른 무인 자동 운반장치는, 이동 경로를 안내하는 지면의 라인을 따라 이동되며 물건을 지정된 장소로 운반하기 위한 무인 자동 운반장치에 있어서, 하부에 이동바퀴가 설치되고, 상기 이동바퀴의 구동 및 조향이 가능한 구동부를 포함하여 구성된 본체프레임과; 상기 본체프레임의 전방에 구비되되, 상기 본체프레임의 전방 양측에서 지면과 평행하게 연장되는 한 쌍의 지지바와, 상기 한 쌍의 지지바의 말단부 하측에 설치되는 이동롤러를 포함하여 구성된 지지프레임과; 상기 지지프레임에서 상부방향으로 수직하게 설치되는 가이드레일과, 일단부가 상기 가이드레일에 연결되는 리프트체인과, 상기 리프트체인의 타단부가 일측에 연결되어 상기 가이드레일을 따라 승·하강 가능하게 구비되는 포크를 포함하여 구성된 포크리프트부와; 상기 지지프레임에 구비되어 상기 포크를 승·하강시키는 유압장치부를; 포함하되, 상기 본체프레임의 하부에 구비되어 상기 지면의 라인을 감지하는 라인감지부와; 상기 본체프레임 또는 상기 포크리프트부의 전방에 구비되어 상기 물건의 위치 및 상기 이동 경로를 촬영하는 촬영부와; 상기 라인감지부에서 감지된 감지정보 및 상기 촬영부에서 촬영된 시각정보를 이용하여 물건을 지정된 장소로 운반할 수 있도록 상기 구동부 및 상기 유압장치부의 작동을 제어하는 제어부를; 더 포함하는 것을 특징으로 한다.BACKGROUND OF THE INVENTION 1. Field of the Invention The present invention relates to an automatic unmanned automatic transportation device, and more particularly, to an automatic unmanned automatic transportation device capable of automatically transporting an object to a designated place along a line of a ground that guides a movement route without a driver operating or operating the transportation device .
The automatic unmanned transportation apparatus according to the present invention is an automatic unmanned transportation apparatus for moving an object along a line of a ground that guides a moving path and transporting an object to a designated place, wherein a moving wheel is provided at a lower portion, And a driver capable of steering; A support frame disposed at a front side of the main body frame, the support frame including a pair of support bars extending parallel to the ground on both sides of the front side of the main frame, and a moving roller provided below the distal ends of the pair of support bars; A lift chain, one end of which is connected to the guide rail, and the other end of the lift chain is connected to one side so as to be able to move up and down along the guide rail, A fork lift portion including a fork; A hydraulic unit provided on the support frame for moving up and down the fork; A line sensing unit provided at a lower portion of the body frame to sense a line of the ground; A photographing unit provided in front of the main frame or the forklift unit for photographing the position of the object and the moving path; A controller for controlling operations of the driving unit and the hydraulic unit so that the object can be transported to a designated place using the sensed information sensed by the line sensing unit and the time information photographed by the photographing unit; And further comprising:
Description
본 발명은 무인 자동 운반장치에 관한 것으로, 보다 상세하게는 운반장치를 운전하거나 조작하는 운전자 없이 이동 경로를 안내하는 지면의 라인을 따라 지정된 장소로 물건을 자동으로 운반할 수 있게 하는 무인 자동 운반장치에 관한 것이다.BACKGROUND OF THE
일반적으로 지게차(forklift)는 팔레트에 적재된 물건을 싣거나 내리는 하역 전용 장비로서, 작업장 등에서 무거운 물건을 보다 용이하게 지정된 장소로 운반할 수 있도록 하는 운반차량이다.In general, a forklift is a loading and unloading device for loading or unloading a pallet. It is a transportation vehicle that allows a heavy object to be easily transported to a designated place in a workplace or the like.
이러한 지게차는 현재 물류센터나 할인매장 또는 설비공장 등에서 물건을 운반하여 적재 또는 이재하는 데 널리 사용되고 있다.These forklifts are now widely used for carrying or loading goods at logistics centers, discount stores or facility factories.
한편, 종래의 지게차를 이용하여 화물을 운반하는 작업중에는 종종 안전사고가 발생하게 되는데, 특히 지게차가 후진하는 경우 후방의 장애물이나 움직이는 물체를 인식하지 못하여 안전사고가 발생되는 경우가 많았다.On the other hand, a safety accident often occurs during the operation of carrying a cargo using a conventional forklift. Especially, when the forklift is backed up, safety accidents occur frequently because the obstacle or moving object is not recognized.
상기와 같은 문제점을 해소하기 위하여 종래의 기술로 대한민국 공개특허공보 제10-2007-0058242호(공개일자: 2007.06.28.) "지게차의 후방 장애물 감지 제어장치" 가 제안된 바 있다.In order to solve the above problems, Korean Patent Laid-Open Publication No. 10-2007-0058242 (published on Jun. 28, 2007) entitled " Device for detecting the rear obstacle of a forklift "
상기 종래기술은 지게차의 후방 프레임에 일정 간격을 두고 다수 설치되는 지게차 후방의 장애물과의 거리를 감지하는 후방감지센서와, 상기 후방감지센서의 감지신호값의 크기에 따라 지게차 후방과 장애물과의 거리가 가까워질수록 지게차의 후진속도를 줄여주는 후진 감속 제어장치를 포함하는 것을 특징으로 하여 지게차 및 지게차의 운전자를 보호할 수 있도록 구성된 기술이다.The rear sensor detects a distance between a rear portion of a forklift and a rear portion of a forklift installed at a predetermined interval in a rear frame of the forklift. The distance between the rear portion of the forklift and the obstacle And a backward deceleration control device for reducing the backward speed of the forklift as the vehicle approaches the forklift and forklift.
하지만, 상기의 종래기술은 지게차의 후진시에는 어느 정도 안정성을 확보할 수 있지만, 상기 종래기술을 포함하는 종래의 대부분의 지게차는 운전자가 직접 지게차를 운전하거나 조작하기 때문에 최근 물류의 양이 증가함에 따라 지게차 운전자들의 작업량 또한 증가하여 운전자의 피로누적으로 인한 조작 실수 등으로 충돌, 낙하 등의 사고가 늘어나고 있어 운전자가 다치는 경우가 발생하는 문제점이 있다.However, in the conventional technology described above, some stability can be ensured when the forklift is backward. However, since most of the conventional forklifts including the conventional technology operate or operate the forklift directly by the driver, Accordingly, the workload of the forklift driver is also increased, so that accidents such as collision and dropping are increased due to an operator's mistake due to accumulation of fatigue, and the driver is injured.
본 발명은 상기와 같은 문제점을 해결하기 위하여 안출된 것으로, 본 발명의 목적은 물건을 들어올릴 수 있도록 본체프레임의 전방으로 포크리프트부를 구비시키고, 이동 경로를 안내하는 지면의 라인을 따라 이동할 수 있도록 본체프레임의 하부에 상기 지면의 라인을 감지하는 라인감지부를 구비시켜 운반장치를 운전하거나 조작하는 운전자 없이 자동으로 물건을 지정된 장소로 운반할 수 있게 하는 무인 자동 운반장치를 제공하는 데에 있다.SUMMARY OF THE INVENTION It is an object of the present invention to provide a forklift unit in front of a main body frame so as to lift an object and to move the main body frame along a line And a line sensing unit for detecting the line of the ground on the lower part of the main body frame so that the driver can be automatically transported to a designated place without a driver operating or operating the transportation apparatus.
상기와 같은 목적을 달성하기 위하여 본 발명에 따른 무인 자동 운반장치는, 이동 경로를 안내하는 지면의 라인을 따라 이동되며 물건을 지정된 장소로 운반하기 위한 무인 자동 운반장치에 있어서, 하부에 이동바퀴가 설치되고, 상기 이동바퀴의 구동 및 조향이 가능한 구동부를 포함하여 구성된 본체프레임과; 상기 본체프레임의 전방에 구비되되, 상기 본체프레임의 전방 양측에서 지면과 평행하게 연장되는 한 쌍의 지지바와, 상기 한 쌍의 지지바의 말단부 하측에 설치되는 이동롤러를 포함하여 구성된 지지프레임과; 상기 지지프레임에서 상부방향으로 수직하게 설치되는 가이드레일과, 일단부가 상기 가이드레일에 연결되는 리프트체인과, 상기 리프트체인의 타단부가 일측에 연결되어 상기 가이드레일을 따라 승·하강 가능하게 구비되는 포크를 포함하여 구성된 포크리프트부와; 상기 지지프레임에 구비되어 상기 포크를 승·하강시키는 유압장치부를; 포함하되, 상기 본체프레임의 하부에 구비되어 상기 지면의 라인을 감지하는 라인감지부와; 상기 본체프레임 또는 상기 포크리프트부의 전방에 구비되어 상기 물건의 위치 및 상기 이동 경로를 촬영하는 촬영부와; 상기 라인감지부에서 감지된 감지정보 및 상기 촬영부에서 촬영된 시각정보를 이용하여 물건을 지정된 장소로 운반할 수 있도록 상기 구동부 및 상기 유압장치부의 작동을 제어하는 제어부를; 더 포함하는 것을 특징으로 한다.In order to achieve the above object, according to the present invention, there is provided an automatic unmanned automatic conveying apparatus for moving an object along a line of a ground guiding a moving route to a designated place, A main body frame including a driving part installed and capable of driving and steering the moving wheels; A support frame disposed at a front side of the main body frame, the support frame including a pair of support bars extending parallel to the ground on both sides of the front side of the main frame, and a moving roller provided below the distal ends of the pair of support bars; A lift chain, one end of which is connected to the guide rail, and the other end of the lift chain is connected to one side so as to be able to move up and down along the guide rail, A fork lift portion including a fork; A hydraulic unit provided on the support frame for moving up and down the fork; A line sensing unit provided at a lower portion of the body frame to sense a line of the ground; A photographing unit provided in front of the main frame or the forklift unit for photographing the position of the object and the moving path; A controller for controlling operations of the driving unit and the hydraulic unit so that the object can be transported to a designated place using the sensed information sensed by the line sensing unit and the time information photographed by the photographing unit; And further comprising:
또한, 본 발명에 따른 무인 자동 운반장치는, 상기 제어부와 무선으로 연계되어 상기 무인 자동 운반장치를 원격으로 컨트롤하는 무선컨트롤러를; 더 포함하되, 상기 제어부는, 상기 무선컨트롤러의 컨트롤신호를 전달받을 수 있는 통신모듈을 포함하여 구성된 것을 특징으로 한다.The automatic unmanned conveying apparatus according to the present invention may further comprise: a wireless controller connected to the control unit by radio to remotely control the unmanned automatic conveying apparatus; Wherein the control unit includes a communication module capable of receiving a control signal of the wireless controller.
또한, 본 발명에 따른 무인 자동 운반장치는, 상기 본체프레임은, 내부에 상기 구동부 및 상기 유압장치부에 전원을 공급하는 축전지를 더 포함하여 구성되고, 상기 본체프레임에 구비되어 물건의 현재 위치 및 운반될 위치를 설정하는 위치설정부를; 더 포함하되, 상기 제어부는, 상기 위치설정부에서 설정된 물건의 위치정보에 따라 물건을 지정된 장소로 운반할 수 있도록 상기 구동부 및 상기 유압장치부를 제어하는 것을 특징으로 한다.According to another aspect of the present invention, there is provided an automatic unmanned conveying apparatus, wherein the main body frame further includes a battery for supplying power to the driving unit and the hydraulic unit, A position setting unit for setting a position to be transported; And the control unit controls the driving unit and the hydraulic unit so that the object can be transported to a designated place according to the position information of the object set by the position setting unit.
상기와 같은 구성에 의하여 본 발명에 따른 무인 자동 운반장치는 본체프레임의 전방으로 포크리프트부가 구비되어 팔레트에 적재된 물건을 쉽게 들어올릴 수 있고, 본체프레임의 하부에 라인감지부가 장착되어 이동 경로를 안내하는 지면의 라인을 따라 이동할 수 있으며, 상기 구성들이 제어부에 의해 자동으로 제어됨으로써 상기 무인 자동 운반장치를 운전하거나 조작하는 운전자 없이 물건을 지정된 장소로 운반할 수 있는 장점이 있다.According to the present invention, there is provided an automatic unmanned automatic transportation device comprising: a forklift provided at a front side of a main body frame to easily lift an object placed on a pallet; It is possible to move along the line of the guiding ground, and the structures are automatically controlled by the control unit, so that the goods can be transported to a designated place without a driver operating or operating the automatic unmanned transportation apparatus.
따라서, 본 발명에 따른 무인 자동 운반장치는 운전자가 필요 없기 때문에 운전자에게 발생할 수 있는 안전사고를 원천적으로 방지할 수 있음은 물론 물류현장의 인력절감, 생산성 향상, 근로환경 개선을 통해 제품이나 서비스의 가격 경쟁력을 높이는 효과가 있다.Accordingly, the automatic unmanned transportation system according to the present invention can prevent a safety accident that may occur to a driver because a driver is not necessary, It is effective to increase price competitiveness.
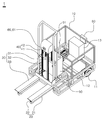
도 1은 본 발명의 일실시예에 따른 무인 자동 운반장치의 사시도
도 2는 본 발명의 일실시예에 따른 무인 자동 운반장치의 내부구성을 도시한 사시도
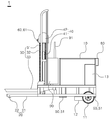
도 3은 본 발명의 일실시예에 따른 무인 자동 운반장치의 내부구성을 도시한 측면도
도 4는 본 발명의 일실시예에 따른 무인 자동 운반장치의 내부구성을 도시한 저면도
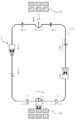
도 5는 본 발명의 일실시예에 따른 무인 자동 운반장치가 물건을 운반하는 과정을 개략적으로 도시한 설명도 1 is a perspective view of an automatic unmanned automatic conveying apparatus according to an embodiment of the present invention;
2 is a perspective view showing the internal structure of the automatic unmanned automatic conveying apparatus according to the embodiment of the present invention.
3 is a side view showing the internal structure of the automatic unmanned automatic transport device according to the embodiment of the present invention
4 is a bottom view illustrating an internal configuration of the automatic unmanned automatic conveying apparatus according to the embodiment of the present invention.
FIG. 5 is a schematic view illustrating a process of transporting goods by the automatic unmanned transportation apparatus according to an embodiment of the present invention. FIG.
이하에서는 도면에 도시된 실시예를 참조하여 본 발명에 따른 무인 자동 운반장치를 보다 상세하게 설명하기로 한다.Hereinafter, the automatic unmanned automatic transport apparatus according to the present invention will be described in detail with reference to the embodiments shown in the drawings.
도 1은 본 발명의 일실시예에 따른 무인 자동 운반장치의 사시도이고, 도 2는 본 발명의 일실시예에 따른 무인 자동 운반장치의 내부구성을 도시한 사시도이며, 도 3은 본 발명의 일실시예에 따른 무인 자동 운반장치의 내부구성을 도시한 측면도이고, 도 4는 본 발명의 일실시예에 따른 무인 자동 운반장치의 내부구성을 도시한 저면도이며, 도 5는 본 발명의 일실시예에 따른 무인 자동 운반장치가 물건을 운반하는 과정을 개략적으로 도시한 설명도이다.FIG. 1 is a perspective view of an automatic unmanned automatic conveying apparatus according to an embodiment of the present invention, FIG. 2 is a perspective view illustrating an internal structure of an automatic unmanned automatic conveying apparatus according to an embodiment of the present invention, FIG. 4 is a bottom view illustrating the internal structure of the automatic unmanned automatic transportation device according to the embodiment of the present invention, and FIG. 5 is a cross-sectional view of an unmanned automatic transportation device according to an embodiment of the present invention. FIG. 2 is an explanatory view schematically showing a process of transporting goods by the automatic unmanned transportation device according to the example.
본 발명에 따른 무인 자동 운반장치(1)는 상기 운반장치(1)를 운전하거나 조작하는 운전자 없이 이동 경로를 안내하는 지면의 라인(L)을 따라 자동으로 이동되며 물건(G)을 지정된 장소로 운반하기 위한 것이다.The automatic
도면을 살펴보면, 본 발명의 일실시예에 따른 무인 자동 운반장치(1)는 본체프레임(10), 지지프레임(20), 포크리프트부(30), 유압장치부(40), 라인감지부(50), 촬영부(60), 무선컨트롤러(70), 위치설정부(80), 제어부(90)를 포함하여 구성된다.The automatic
상기 본체프레임(10)은 도 2 내지 4에 도시된 바와 같이 다수개의 지지부재가 서로 연결되어 외형을 형성하고, 외부 및 내부에 본 발명에 따른 무인 자동 운반장치(1)의 다른 구성요소들이 구비 및 설치되어 지지되는 지지체 역할을 하는 것으로, 하부에는 이동바퀴(11)가 설치되고, 상기 본체프레임(10)의 내부 상기 이동바퀴(11)와 인접한 위치에 상기 이동바퀴(11)의 구동 및 조향이 가능하도록 하는 구동부(12)가 설치된다. 이때, 상기 구동부(12)는 주행모터와 조향모터를 포함하여 구성될 수 있다.As shown in FIGS. 2 to 4, the
한편, 상기 이동바퀴(11)는 도 2 또는 도 4에 도시된 본 발명의 일실시예와 같이 상기 본체프레임의 폭방향 양측으로 한 쌍의 이동바퀴(11)가 각각 설치될 수 있으며, 도면에 도시되지는 않았지만 한 쌍의 이동바퀴(11)를 연결하는 구동축의 양측에 고정 설치되어 구성될 수 있다.2 and 4, the
또한, 상기 이동바퀴(11)는 도면에 도시되지는 않았지만 상기 본체프레임(10)의 전방측 하부에 양측으로 설치되는 한 쌍의 전륜과, 상기 본체프레임(10)의 후방측 하부에 양측으로 설치되는 한 쌍의 후륜으로 분리되어 구성될 수 있다.Although not shown in the drawing, the moving
상기 본체프레임(10)은 내부에 상기 무인 자동 운반장치(1)가 작동할 수 있도록 상기 구동부(12) 및 상기 유압장치부(40)에 전원을 공급하는 축전지(13)를 더 포함하여 구성된다.The
도 1에 도시된 바와 같이 본 발명에 따른 무인 자동 운반장치(1)는 상기 본체프레임(10)을 덮어주는 커버부재(C)를 더 포함할 수 있다.As shown in FIG. 1, the automatic unmanned
상기 지지프레임(20)은 도 2 내지 4에 도시된 바와 같이 상기 본체프레임(10)의 전방에 구비되는 것으로, 상기 본체프레임(10)의 전방 양측에서 앞쪽방향으로 지면과 평행하게 연장되는 한 쌍의 지지바(21)와 상기 한 쌍의 지지바(21)의 말단부 하측에 설치되는 이동롤러(22)를 포함하여 구성된다.2 to 4, the
상기 지지프레임(20)은 후술하는 상기 포크리프트부(30)의 포크(33)를 이용하여 무거운 물건(G)을 들어올리는 경우 상기 무인 자동 운반장치(1)가 기울어지거나 전복되지 않도록 균형을 잡아주는 역할을 한다.When the heavy object G is lifted by using the
또한, 상기 지지바(21)에 설치되는 상기 이동롤러(22)는 상기 무인 자동 운반장치(1)가 이동하는 경우 지면과의 마찰을 줄여 이동이 용이하도록 하는 구성으로, 본 발명에 따른 일실시예에서는 상기 본체프레임(10)에 설치되는 이동바퀴(11)가 후륜 역할을 하고, 상기 지지바(21)에 설치되는 상기 이동롤러(22)가 전륜 역할을 하게 되는 것이다.In addition, the moving
상기 포크리프트부(30)는 통상적으로 사용되는 팔레트 상에 적재된 물건(G)을 들어올릴 수 있도록 구성된 것으로, 가이드레일(31), 리프트체인(32), 포크(33)를 포함하여 구성된다.The
도 1 또는 도 2에 도시된 바와 같이 상기 가이드레일(31)은 상기 지지프레임(20)에 상부방향으로 수직하게 설치되고, 상기 리프트체인(32)은 일단부가 상기 가이드레일(31)의 가로지지부재에 연결되고 타단부가 상기 포크(33)의 일측에 연결되며, 상기 포크(33)는 상기 가이드레일(31)을 따라 상기 리프트체인(32)에 의해 승·하강 가능하게 구비된다.1 and 2, the
상기 포크(33)는 도 1 또는 도 2에 도시된 바와 같이 한 쌍으로 구성되고, 상기 포크(33)의 일단부가 상기 가이드레일(31)에 상하방향으로 슬라이딩 가능하게 결합되며, 상기 무인 자동 운반장치(1)의 전진방향으로 상기 지지프레임(20)의 지지바(21)와 평행하게 일정길이 연장되어 형성된다. 1 and 2, one end of the
상기 한 쌍의 포크(33)는 좌우방향으로 슬라이딩 이동되며 상호 이격된 간격이 조절될 수 있도록 구성될 수 있다.The pair of
상기 유압장치부(40)는 상기 지지프레임(20)에 구비되어 상기 포크(33)를 승·하강시키는 구성으로, 유압실린더(41)로 이루어지는 것이 바람직하다.The
상기 유압장치부(40)는 도 1 또는 도 2에 도시된 바와 같이 하단부가 상기 지지프레임(20)에 고정되고 상부방향으로 수직하게 세워져 설치된다.1 or 2, the lower end of the
상기 유압장치부(40)의 상단부에는 도 1 내지 도 3에 도시된 바와 같이 내부에 상기 리프트체인(32)을 권취하는 체인풀리(미도시)가 설치된 풀리박스(42)가 구비된다.1 to 3, a
상기 라인감지부(50)는 상기 본체프레임(10)의 하부에 구비되어 이동 경로를 안내하는 상기 지면의 라인(L)을 감지하는 구성으로, 상기 지면의 라인(L)을 감지하는 라인감지센서(51)가 구비된다.The line sensing unit 50 is disposed below the
상기 라인감지부(50)는 도 4에 도시된 본 발명에 따른 일실시예에서와 같이 상기 지면의 라인(L)의 폭방향 양측에 배치되어 상기 본체프레임의 하부 즉 저면에 다수개가 설치될 수 있다.The line sensing unit 50 may be disposed on both sides in the width direction of the line L of the paper as shown in FIG. 4 according to the present invention, and a plurality of the line sensing units 50 may be installed on the lower or bottom surface of the main frame .
상기 라인감지부(50)에 의해 상기 무인 자동 운반장치(1)가 이동 경로를 이탈하지 않고 자동으로 물건(G)을 지정된 장소에 정확하게 운반할 수 있게 되는 것이다.The automatic
이때, 상기 라인감지센서(51)는 상기 지면의 라인(L)이 마그네틱 라인인 경우 상기 마그네틱 라인을 감지하는 마그네틱감지센서가 구비되고, 상기 지면의 라인(L)이 컬러 테이프인 경우 상기 컬러 테이프를 감지하는 컬러감지센서가 구비된다.If the line L on the paper surface is a color tape, the line sensor 51 may include a magnetic sensor for sensing the magnetic line when the line L on the paper surface is a magnetic line. And a color sensor for sensing the color of the image.
상기 촬영부(60)는 상기 본체프레임(10) 또는 상기 포크리프트부(30)의 전방에 구비되어 상기 물건(G)의 위치 및 상기 이동 경로를 촬영하는 구성으로, 카메라(61)가 구비된다.The photographing unit 60 is provided in front of the
도 1 내지 도 3에 도시된 바와 같이 본 발명에 따른 일실시예에서는 상기 촬영부(60)의 카메라(61)를 전방의 시야 확보가 용이한 위치인 상기 유압장치부(40)의 상단부에 설치된 상리 풀리박스(42)의 전면에 설치되게 하였으나, 시야 확보가 용이한 위치라면 상기 본체프레임(10), 상기 포크리프트부(30) 등의 적당한 위치 어디에든 설치될 수 있다.1 to 3, in an embodiment of the present invention, the camera 61 of the photographing unit 60 is installed at the upper end of the
상기 촬영부(60)에 의해 상기 물건(G)의 위치를 정확히 파악할 수 있고, 상기 무인 자동 운반장치(1)가 상기 지면의 라인(L)에서 이탈된 위치에 있을 경우 상기 지면의 라인(L)으로 복귀할 수 있게 되는 것이다.It is possible to accurately grasp the position of the object G by the photographing unit 60. When the automatic unmanned automatic
상기 무선컨트롤러(70)는 도 1에 도시된 바와 같이 상기 제어부(90)와 무선으로 연계되어 상기 무인 자동 운반장치(1)를 원격으로 컨트롤할 수 있도록 하는 구성으로, 작업자가 원격으로 상기 무인 자동 운반장치(1)를 수동제어할 수 있게 한다.As shown in FIG. 1, the
이때, 상기 제어부(90)에는 도 1에 도시된 바와 같이 상기 무선컨트롤러(70)의 컨트롤신호를 전달받을 수 있는 통신모듈(91)이 포함되어 구성된다.1, the
상기 위치설정부(80)는 상기 본체프레임(10)에 구비되어 물건(G)의 현재 위치 및 이동시킬 위치를 설정하는 구성이다.The
도 3에 도시된 바와 같이 본 발명에 따른 일실시예에서는 상기 위치설정부(80)를 작업자가 조작하기 용이한 위치인 상기 본체프레임(10)의 후면 상단부에 배치되도록 하였으나, 작업자가 상기 위치설정부(80)를 조작할 수 있는 위치라면 상기 본체프레임(10)의 상면 또는 측면 등 어디에든 설치될 수 있다.As shown in FIG. 3, in the embodiment of the present invention, the
상기 위치설정부(80)에 의해 물건(G)의 현재 위치 및 운반될 위치가 설정되면 도 5에 도시된 바와 같이 상기 무인 자동 운반장치(1)가 상기 지면의 라인(L)을 따라 자동으로 물건(G)의 현재 위치로 이동하게 되고, 상기 포크(33)를 이용하여 물건(G)을 들어올린 후 다시 상기 지면의 라인(L)을 따라 이동하여 물건(G)을 지정된 위치에 정확히 운반하게 된다.When the current position of the object G and the position to be transported are set by the
상기 제어부(90)는 상기 위치설정부(80)에서 설정된 물건(G)의 현재 위치 및 운반될 위치의 위치정보에 따라 상기 라인감지부(50)에서 감지된 감지정보 및 상기 촬영부(60)에서 촬영된 시각정보를 이용하여 물건(G)을 지정된 장소로 운반할 수 있도록 상기 구동부(12) 및 상기 유압장치부(40)의 작동을 제어하는 구성으로 상기 본체프레임(10)에 구비된다.The
상기와 같은 구성요소들의 유기적인 결합관계에 의하여 본 발명의 일실시예에 따른 무인 자동 운반장치는 상기 운반장치를 운전하거나 조작하는 운전자 없이 지면에 형성된 이동 경로 안내라인을 따라 이동되며 자동으로 물건을 지정된 장소로 운반할 수 있게 되는 것이다.The automatic unmanned automatic transport apparatus according to an embodiment of the present invention is moved along a travel route guide line formed on the ground without a driver operating or operating the transport apparatus according to the organic connection relationship of the above- So that it can be transported to the designated place.
따라서, 본 발명에 따른 무인 자동 운반장치는 운전자가 필요 없기 때문에 운전자에게 발생할 수 있는 안전사고를 원천적으로 방지할 수 있음은 물론 물류현장의 인력절감, 생산성 향상, 근로환경 개선을 통해 제품이나 서비스의 가격 경쟁력을 높일 수 있게 되는 것이다.Accordingly, the automatic unmanned transportation system according to the present invention can prevent a safety accident that may occur to a driver because a driver is not necessary, Price competitiveness can be increased.
앞에서 설명되고 도면에서 도시된 무인 자동 운반장치는 본 발명을 실시하기 위한 하나의 실시예에 불과하며, 본 발명의 기술적 사상을 한정하는 것으로 해석되어서는 안된다. 본 발명의 보호범위는 이하의 특허청구범위에 기재된 사항에 의해서만 정하여지며, 본 발명의 요지를 벗어남이 없이 개량 및 변경된 실시예는 본 발명이 속하는 기술분야에서 통상의 지식을 가진 자에게 자명한 것인 한 본 발명의 보호범위에 속한다고 할 것이다.The automatic unmanned automatic transport apparatus described above and shown in the drawings is only one embodiment for carrying out the present invention and should not be construed as limiting the technical idea of the present invention. The scope of protection of the present invention is defined only by the matters set forth in the following claims, and the embodiments improved and changed without departing from the gist of the present invention are obvious to those having ordinary skill in the art to which the present invention belongs It will be understood that the invention is not limited thereto.
1
무인 자동 운반장치
10
본체프레임
11
이동바퀴
12
구동부
13
축전지
20
지지프레임
21
지지바
22
이동롤러
30
포크리프트부
31
가이드레일
32
리프트체인
33
포크
40
유압장치부
41
유압실린더
42
풀리박스
50
라인감지부
51
라인감지센서
60
촬영부
61
카메라
70
무선컨트롤러
80
위치설정부
90
제어부
91
통신모듈
L
라인, C
커버부재, G
물건1 Unmanned Automatic Carrier
10 Body frame
11 Moving wheels
12 driver
13 Battery
20 support frame
21 Support bars
22 moving roller
30 fork lift section
31 Guide rail
32 lift chain
33 forks
40 Hydraulic unit
41 Hydraulic cylinders
42 pulley box
50 Line Sensing Branch
51 line sensor
60 Shooting section
61 Camera
70 Wireless Controller
80 Position setting unit
90 control unit
91 communication module
L line, C cover member, G object
Claims (3)
하부에 이동바퀴가 설치되고, 상기 이동바퀴의 구동 및 조향이 가능한 구동부를 포함하여 구성된 본체프레임과;
상기 본체프레임의 전방에 구비되되, 상기 본체프레임의 전방 양측에서 지면과 평행하게 연장되는 한 쌍의 지지바와, 상기 한 쌍의 지지바의 말단부 하측에 설치되는 이동롤러를 포함하여 구성된 지지프레임과;
상기 지지프레임에서 상부방향으로 수직하게 설치되는 가이드레일과, 일단부가 상기 가이드레일에 연결되는 리프트체인과, 상기 리프트체인의 타단부가 일측에 연결되어 상기 가이드레일을 따라 승·하강 가능하게 구비되는 포크를 포함하여 구성된 포크리프트부와;
상기 지지프레임에 구비되어 상기 포크를 승·하강시키는 유압장치부를; 포함하되,
상기 본체프레임의 하부에 구비되어 상기 지면의 라인을 감지하는 라인감지부와;
상기 본체프레임 또는 상기 포크리프트부의 전방에 구비되어 상기 물건의 위치 및 상기 이동 경로를 촬영하는 촬영부와;
상기 라인감지부에서 감지된 감지정보 및 상기 촬영부에서 촬영된 시각정보를 이용하여 물건을 지정된 장소로 운반할 수 있도록 상기 구동부 및 상기 유압장치부의 작동을 제어하는 제어부를; 더 포함하는 것을 특징으로 하는 무인 자동 운반장치.An automatic unmanned transportation device for moving an object along a line of a ground that guides a moving path to a designated place,
A main body frame having a moving wheel installed at a lower portion thereof and configured to include a driving portion capable of driving and steering the moving wheels;
A support frame disposed at a front side of the main body frame, the support frame including a pair of support bars extending parallel to the ground on both sides of the front side of the main frame, and a moving roller provided below the distal ends of the pair of support bars;
A lift chain, one end of which is connected to the guide rail, and the other end of the lift chain is connected to one side so as to be able to move up and down along the guide rail, A fork lift portion including a fork;
A hydraulic unit provided on the support frame for moving up and down the fork; Including,
A line sensing unit provided at a lower portion of the body frame to sense a line of the ground;
A photographing unit provided in front of the main frame or the forklift unit for photographing the position of the object and the moving path;
A controller for controlling operations of the driving unit and the hydraulic unit so that the object can be transported to a designated place using the sensed information sensed by the line sensing unit and the time information photographed by the photographing unit; Further comprising an automatic unmanned conveying device.
상기 제어부와 무선으로 연계되어 상기 무인 자동 운반장치를 원격으로 컨트롤하는 무선컨트롤러를; 더 포함하되,
상기 제어부는, 상기 무선컨트롤러의 컨트롤신호를 전달받을 수 있는 통신모듈을 포함하여 구성된 것을 특징으로 하는 무인 자동 운반장치.The method according to claim 1,
A wireless controller that wirelessly connects with the controller to remotely control the automatic unmanned conveying device; Further included,
Wherein the control unit comprises a communication module capable of receiving a control signal of the wireless controller.
상기 본체프레임은, 내부에 상기 구동부 및 상기 유압장치부에 전원을 공급하는 축전지를 더 포함하여 구성되고,
상기 본체프레임에 구비되어 물건의 현재 위치 및 운반될 위치를 설정하는 위치설정부를; 더 포함하되,
상기 제어부는, 상기 위치설정부에서 설정된 물건의 위치정보에 따라 물건을 지정된 장소로 운반할 수 있도록 상기 구동부 및 상기 유압장치부를 제어하는 것을 특징으로 하는 무인 자동 운반장치.3. The method according to claim 1 or 2,
Wherein the main body frame further includes a storage battery for supplying power to the driving unit and the hydraulic unit,
A position setting unit provided in the main body frame for setting a current position of the object and a position to be carried; Further included,
Wherein the control unit controls the driving unit and the hydraulic unit so that the object can be transported to a designated place according to the position information of the object set by the position setting unit.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020140019883A KR20150098508A (en) | 2014-02-20 | 2014-02-20 | Automatic guided vehicle |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020140019883A KR20150098508A (en) | 2014-02-20 | 2014-02-20 | Automatic guided vehicle |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| KR20150098508A true KR20150098508A (en) | 2015-08-28 |
Family
ID=54059916
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020140019883A Ceased KR20150098508A (en) | 2014-02-20 | 2014-02-20 | Automatic guided vehicle |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR20150098508A (en) |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN106677072A (en) * | 2017-01-26 | 2017-05-17 | 中国人民解放军国防科学技术大学 | Detachable highway steel bridge carrying and erecting vehicle of average height installation |
| KR20210026927A (en) | 2019-09-02 | 2021-03-10 | 김강현 | Unmanned Carrier for Forklift |
| SE544238C2 (en) * | 2018-04-23 | 2022-03-08 | Toyota Mat Handling Manufacturing Sweden Ab | Material handling vehicle |
| KR20220103260A (en) * | 2021-01-15 | 2022-07-22 | 한남대학교 산학협력단 | Navigation system for autonomous driving of heavy equipment using cameras |
| KR20220106313A (en) * | 2021-01-22 | 2022-07-29 | 경북대학교 산학협력단 | User Designating Line Tracking Autonomous Driving Sprayer |
| WO2023278496A1 (en) * | 2021-06-28 | 2023-01-05 | Moog Inc. | Autonomous load moving electric vehicle |
-
2014
- 2014-02-20 KR KR1020140019883A patent/KR20150098508A/en not_active Ceased
Cited By (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN106677072A (en) * | 2017-01-26 | 2017-05-17 | 中国人民解放军国防科学技术大学 | Detachable highway steel bridge carrying and erecting vehicle of average height installation |
| CN106677072B (en) * | 2017-01-26 | 2019-04-09 | 中国人民解放军国防科技大学 | Detachable highway steel bridge carrying and erecting vehicle with general height |
| SE544238C2 (en) * | 2018-04-23 | 2022-03-08 | Toyota Mat Handling Manufacturing Sweden Ab | Material handling vehicle |
| KR20210026927A (en) | 2019-09-02 | 2021-03-10 | 김강현 | Unmanned Carrier for Forklift |
| KR20220103260A (en) * | 2021-01-15 | 2022-07-22 | 한남대학교 산학협력단 | Navigation system for autonomous driving of heavy equipment using cameras |
| KR20220106313A (en) * | 2021-01-22 | 2022-07-29 | 경북대학교 산학협력단 | User Designating Line Tracking Autonomous Driving Sprayer |
| WO2023278496A1 (en) * | 2021-06-28 | 2023-01-05 | Moog Inc. | Autonomous load moving electric vehicle |
| US12497276B2 (en) | 2021-06-28 | 2025-12-16 | Moog Inc. | Autonomous load moving electric vehicle |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR101857347B1 (en) | Uumaned Truck for Roll Product Transferring | |
| JP4666213B2 (en) | Goods storage equipment | |
| JP6733138B2 (en) | Storage facility using a self-propelled carrier | |
| KR101416412B1 (en) | Component conveying system for automotive assembly line | |
| CN114435833B (en) | Article accommodating apparatus | |
| CN115605419B (en) | Loading system for loading and unloading trucks | |
| KR101462527B1 (en) | Automated guided vehicles | |
| JP5418825B2 (en) | Article transfer device and stacker crane equipped with the same | |
| KR101377662B1 (en) | Double loading type unmanned forklift | |
| CN115605421B (en) | Loading system for loading and unloading trucks using transverse pallets | |
| KR20190044898A (en) | samrt automatic freight mobility | |
| JP5534355B2 (en) | Goods storage equipment | |
| JP6434715B2 (en) | Transport cart control system | |
| CN210312597U (en) | Handling system | |
| JP4314521B2 (en) | Article conveying device | |
| JPH06100108A (en) | Rolled article transfer device | |
| KR200467883Y1 (en) | Distribution transfer system | |
| CN110482260B (en) | Loading and unloading system | |
| JP2019078002A (en) | Three-dimensional parking device provided with external vehicle loading and unloading section | |
| JP2003002190A (en) | Automatic guided vehicle bumper device | |
| JPH0558403A (en) | Automatic warehouse equipment | |
| KR20200021990A (en) | Forklift including clamping device for forklift and clamping device | |
| CN114644188A (en) | Rotary transfer trolley for cylindrical materials | |
| CN220765631U (en) | Heavy-duty railway vehicle | |
| JP2007217076A (en) | Carrying vehicle |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A201 | Request for examination | ||
| PA0109 | Patent application |
Patent event code: PA01091R01D Comment text: Patent Application Patent event date: 20140220 |
|
| PA0201 | Request for examination | ||
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
Comment text: Notification of reason for refusal Patent event date: 20150216 Patent event code: PE09021S01D |
|
| E601 | Decision to refuse application | ||
| PE0601 | Decision on rejection of patent |
Patent event date: 20150824 Comment text: Decision to Refuse Application Patent event code: PE06012S01D Patent event date: 20150216 Comment text: Notification of reason for refusal Patent event code: PE06011S01I |
|
| PG1501 | Laying open of application |