JP6794879B2 - 作業車両用の人物検知システムおよびこれを備える作業車両 - Google Patents
作業車両用の人物検知システムおよびこれを備える作業車両 Download PDFInfo
- Publication number
- JP6794879B2 JP6794879B2 JP2017046830A JP2017046830A JP6794879B2 JP 6794879 B2 JP6794879 B2 JP 6794879B2 JP 2017046830 A JP2017046830 A JP 2017046830A JP 2017046830 A JP2017046830 A JP 2017046830A JP 6794879 B2 JP6794879 B2 JP 6794879B2
- Authority
- JP
- Japan
- Prior art keywords
- image data
- detection
- person
- person detection
- deviation
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images



Classifications
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T7/00—Image analysis
- G06T7/20—Analysis of motion
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60R—VEHICLES, VEHICLE FITTINGS, OR VEHICLE PARTS, NOT OTHERWISE PROVIDED FOR
- B60R1/00—Optical viewing arrangements; Real-time viewing arrangements for drivers or passengers using optical image capturing systems, e.g. cameras or video systems specially adapted for use in or on vehicles
- B60R1/20—Real-time viewing arrangements for drivers or passengers using optical image capturing systems, e.g. cameras or video systems specially adapted for use in or on vehicles
- B60R1/22—Real-time viewing arrangements for drivers or passengers using optical image capturing systems, e.g. cameras or video systems specially adapted for use in or on vehicles for viewing an area outside the vehicle, e.g. the exterior of the vehicle
- B60R1/23—Real-time viewing arrangements for drivers or passengers using optical image capturing systems, e.g. cameras or video systems specially adapted for use in or on vehicles for viewing an area outside the vehicle, e.g. the exterior of the vehicle with a predetermined field of view
- B60R1/24—Real-time viewing arrangements for drivers or passengers using optical image capturing systems, e.g. cameras or video systems specially adapted for use in or on vehicles for viewing an area outside the vehicle, e.g. the exterior of the vehicle with a predetermined field of view in front of the vehicle
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66C—CRANES; LOAD-ENGAGING ELEMENTS OR DEVICES FOR CRANES, CAPSTANS, WINCHES, OR TACKLES
- B66C13/00—Other constructional features or details
- B66C13/16—Applications of indicating, registering, or weighing devices
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66C—CRANES; LOAD-ENGAGING ELEMENTS OR DEVICES FOR CRANES, CAPSTANS, WINCHES, OR TACKLES
- B66C13/00—Other constructional features or details
- B66C13/18—Control systems or devices
- B66C13/46—Position indicators for suspended loads or for crane elements
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66C—CRANES; LOAD-ENGAGING ELEMENTS OR DEVICES FOR CRANES, CAPSTANS, WINCHES, OR TACKLES
- B66C15/00—Safety gear
- B66C15/06—Arrangements or use of warning devices
- B66C15/065—Arrangements or use of warning devices electrical
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66C—CRANES; LOAD-ENGAGING ELEMENTS OR DEVICES FOR CRANES, CAPSTANS, WINCHES, OR TACKLES
- B66C23/00—Cranes comprising essentially a beam, boom, or triangular structure acting as a cantilever and mounted for translatory of swinging movements in vertical or horizontal planes or a combination of such movements, e.g. jib-cranes, derricks, tower cranes
- B66C23/88—Safety gear
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T7/00—Image analysis
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T7/00—Image analysis
- G06T7/70—Determining position or orientation of objects or cameras
- G06T7/73—Determining position or orientation of objects or cameras using feature-based methods
- G06T7/74—Determining position or orientation of objects or cameras using feature-based methods involving reference images or patches
-
- G—PHYSICS
- G08—SIGNALLING
- G08B—SIGNALLING SYSTEMS, e.g. PERSONAL CALLING SYSTEMS; ORDER TELEGRAPHS; ALARM SYSTEMS
- G08B25/00—Alarm systems in which the location of the alarm condition is signalled to a central station, e.g. fire or police telegraphic systems
-
- G—PHYSICS
- G08—SIGNALLING
- G08B—SIGNALLING SYSTEMS, e.g. PERSONAL CALLING SYSTEMS; ORDER TELEGRAPHS; ALARM SYSTEMS
- G08B29/00—Checking or monitoring of signalling or alarm systems; Prevention or correction of operating errors, e.g. preventing unauthorised operation
- G08B29/18—Prevention or correction of operating errors
- G08B29/20—Calibration, including self-calibrating arrangements
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N7/00—Television systems
- H04N7/18—Closed-circuit television [CCTV] systems, i.e. systems in which the video signal is not broadcast
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N7/00—Television systems
- H04N7/18—Closed-circuit television [CCTV] systems, i.e. systems in which the video signal is not broadcast
- H04N7/183—Closed-circuit television [CCTV] systems, i.e. systems in which the video signal is not broadcast for receiving images from a single remote source
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60R—VEHICLES, VEHICLE FITTINGS, OR VEHICLE PARTS, NOT OTHERWISE PROVIDED FOR
- B60R2300/00—Details of viewing arrangements using cameras and displays, specially adapted for use in a vehicle
- B60R2300/80—Details of viewing arrangements using cameras and displays, specially adapted for use in a vehicle characterised by the intended use of the viewing arrangement
- B60R2300/8093—Details of viewing arrangements using cameras and displays, specially adapted for use in a vehicle characterised by the intended use of the viewing arrangement for obstacle warning
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/24—Safety devices, e.g. for preventing overload
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/26—Indicating devices
- E02F9/261—Surveying the work-site to be treated
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T2207/00—Indexing scheme for image analysis or image enhancement
- G06T2207/10—Image acquisition modality
- G06T2207/10016—Video; Image sequence
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T2207/00—Indexing scheme for image analysis or image enhancement
- G06T2207/30—Subject of image; Context of image processing
- G06T2207/30248—Vehicle exterior or interior
- G06T2207/30252—Vehicle exterior; Vicinity of vehicle
Landscapes
- Engineering & Computer Science (AREA)
- Multimedia (AREA)
- Mechanical Engineering (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Computer Vision & Pattern Recognition (AREA)
- Theoretical Computer Science (AREA)
- Signal Processing (AREA)
- Computer Security & Cryptography (AREA)
- Emergency Management (AREA)
- Business, Economics & Management (AREA)
- Automation & Control Theory (AREA)
- Closed-Circuit Television Systems (AREA)
- Image Analysis (AREA)
- Alarm Systems (AREA)
Description
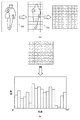
図7(b)に示すように、ずれ判定部21cは、画像識別境界B2に照らし合わせて、最も高い類似度が高類似度グループと低類似度グループとのうち、いずれのグループに属するか否か判定する。ずれ判定部21cは、最も高い類似度が高類似度グループに属する場合、すなわち、判定ヒストグラムhdと基準ヒストグラムh(r)との類似度が高い場合、判定範囲Edの画像データと類似範囲Esの画像データとが一致していると判定する。
その結果、算出したHOG特徴量が歩行者グループ、自転車グループおよびバイクグループのいずれかに属する場合、制御装置21はステップをステップS230に移行させる。
一方、算出したHOG特徴量が歩行者グループ、自転車グループおよびバイクグループのいずれかに属さない場合、すなわち、算出したHOG特徴量が人物のものではない場合、制御装置21はステップをステップS240に移行させる。
その結果、算出した判定ヒストグラムhdと特定した基準ヒストグラムh(r)との類似度が高類似度グループに属している場合、制御装置21はステップをステップS350に移行させる。
一方、算出した判定ヒストグラムhdと特定した基準ヒストグラムh(r)との類似度が低類似度グループに属している場合、制御装置21はステップをステップS310に移行させる。
その結果、算出したユークリッド距離Lが許容値Tよりも大きい場合、制御装置21はステップをステップS370に移行させる。
一方、算出したユークリッド距離Lが許容値Tよりも大きくない場合、制御装置21はステップをステップS390に移行させる。
その結果、算出したユークリッド距離Lが許容値Tよりも大きいと判定された累積回数がN回である場合、制御装置21はステップをステップS380に移行させる。
一方、算出したユークリッド距離Lが許容値Tよりも大きいと判定された累積回数がN回未満である場合、制御装置21はステップをステップS410に移行させる。
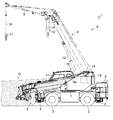
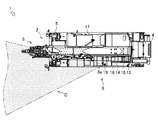
18 人物検知システム
19 カメラ
21 制御装置
21a 表示制御部
21b 人物検知部
21c ずれ判定部
21d 報知部
D 検知領域
Dd 検知画像データ
Sd 基準画像データ
Claims (4)
- 作業車両用の人物検知システムであって、
前記作業車両の一部を含む所定の領域を検知領域として、前記検知領域の検知画像データを取得する画像データ取得手段と、
前記画像データ取得手段が基準位置に配置されている状態で取得した検知画像データに含まれる前記作業車両の画像データが前記検知領域の基準画像データとして設定され、
前記画像データ取得手段が任意の時点で取得した前記検知領域の検知画像データと前記基準画像データとを比較して前記画像データ取得手段の位置が基準位置に対してずれが生じているか判定するずれ判定部と、
前記画像データ取得手段の位置にずれが生じている旨を報知する報知手段と、を備え、
前記ずれ判定部は、
前記画像データ取得手段の位置が基準位置に対してずれが生じているかを判定する際に、SVM学習のアルゴリズムを利用して、任意の時点で取得した前記検知領域の検知画像データと前記基準画像データとの比較を行う、作業車両用の人物検知システム。 - 画像表示手段を更に備え、
前記ずれ判定部が前記画像データ取得手段の位置にずれが生じていると判定すると、前記画像表示手段に前記基準画像データに基づく確認用図形を前記検知領域の画像データに重畳表示させる請求項1に記載の作業車両用の人物検知システム。 - 前記確認用図形に許容される前記検知領域のずれ幅を示すずれ幅確認用図形が合わせて表示される請求項2に記載の作業車両用の人物検知システム。
- 請求項1から請求項3のいずれか一項に記載の作業車両用の人物検知システムを備える作業車両。
Priority Applications (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2017046830A JP6794879B2 (ja) | 2017-03-10 | 2017-03-10 | 作業車両用の人物検知システムおよびこれを備える作業車両 |
| PCT/JP2018/009293 WO2018164273A1 (ja) | 2017-03-10 | 2018-03-09 | 作業車両用の人物検知システムおよびこれを備える作業車両 |
| EP18763563.6A EP3595298B1 (en) | 2017-03-10 | 2018-03-09 | Human detection system for work vehicle, and work vehicle equipped with same |
| US16/488,070 US11120558B2 (en) | 2017-03-10 | 2018-03-09 | Human detection system for work vehicle, and work vehicle equipped with same |
| CN201880015560.0A CN110383831B (zh) | 2017-03-10 | 2018-03-09 | 作业车辆用的人员检测系统和具备该系统的作业车辆 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2017046830A JP6794879B2 (ja) | 2017-03-10 | 2017-03-10 | 作業車両用の人物検知システムおよびこれを備える作業車両 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2018152685A JP2018152685A (ja) | 2018-09-27 |
| JP6794879B2 true JP6794879B2 (ja) | 2020-12-02 |
Family
ID=63447885
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2017046830A Active JP6794879B2 (ja) | 2017-03-10 | 2017-03-10 | 作業車両用の人物検知システムおよびこれを備える作業車両 |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US11120558B2 (ja) |
| EP (1) | EP3595298B1 (ja) |
| JP (1) | JP6794879B2 (ja) |
| CN (1) | CN110383831B (ja) |
| WO (1) | WO2018164273A1 (ja) |
Families Citing this family (14)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| SE541180C2 (en) * | 2017-04-03 | 2019-04-23 | Cargotec Patenter Ab | Driver assistance system for a vehicle provided with a crane using 3D representations |
| JP6926021B2 (ja) * | 2018-03-29 | 2021-08-25 | ヤンマーパワーテクノロジー株式会社 | 作業車両 |
| US10664997B1 (en) * | 2018-12-04 | 2020-05-26 | Almotive Kft. | Method, camera system, computer program product and computer-readable medium for camera misalignment detection |
| US12043527B2 (en) | 2019-05-17 | 2024-07-23 | Kobelco Construction Machinery Co., Ltd. | Work machine and video display control method for work machine |
| JP7464367B2 (ja) * | 2019-09-27 | 2024-04-09 | 新明和工業株式会社 | 塵芥収集車 |
| CN110844785B (zh) * | 2019-11-28 | 2020-12-29 | 重庆中星微人工智能芯片技术有限公司 | 用于生成塔机吊臂信息的方法、装置、设备和介质 |
| JP2021110631A (ja) * | 2020-01-10 | 2021-08-02 | 株式会社デンソー | 検出器の姿勢・位置検出システムおよび検出器の姿勢・位置検出方法 |
| DE102020107016B4 (de) | 2020-03-13 | 2024-06-20 | Mekra Lang Gmbh & Co. Kg | Verfahren zum Verifizieren eines indirekten Sichtsystems sowie indirektes Sichtsystem eines Fahrzeugs |
| JP7428052B2 (ja) | 2020-03-31 | 2024-02-06 | コベルコ建機株式会社 | 作業機械の周囲検知装置 |
| JP7409240B2 (ja) * | 2020-07-02 | 2024-01-09 | 株式会社豊田自動織機 | 障害物検出装置及び障害物検出方法 |
| JP7619089B2 (ja) * | 2021-03-03 | 2025-01-22 | 株式会社タダノ | 後部旋回干渉監視装置 |
| CN114988283B (zh) * | 2022-05-28 | 2025-09-16 | 聚时科技(上海)有限公司 | 一种面向自动化桥吊的高精度船舱位实时检测系统 |
| CN116580182B (zh) * | 2023-04-13 | 2024-06-18 | 北京金和网络股份有限公司 | 一种自动调整的目标检测的方法、系统、设备及存储介质 |
| CN116229692A (zh) * | 2023-05-08 | 2023-06-06 | 陕西汇天广科信息科技有限公司 | 一种监控视频安全系统 |
Family Cites Families (20)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP3268325B2 (ja) * | 1993-01-19 | 2002-03-25 | アイシン精機株式会社 | 車上認識対象画像デ−タの前処理方法 |
| JP4045862B2 (ja) * | 2002-06-03 | 2008-02-13 | 日産自動車株式会社 | 車載カメラの光軸ずれ検出装置 |
| JP5208790B2 (ja) * | 2009-02-04 | 2013-06-12 | アイシン精機株式会社 | 画像処理装置、画像処理方法ならびにプログラム |
| JP5269026B2 (ja) * | 2010-09-29 | 2013-08-21 | 日立建機株式会社 | 作業機械の周囲監視装置 |
| JP2012098983A (ja) * | 2010-11-04 | 2012-05-24 | Fujitsu Ltd | 物体検出装置、物体検出方法及びプログラム |
| JP2013182550A (ja) * | 2012-03-05 | 2013-09-12 | Sumitomo Electric Ind Ltd | 車両検出装置、車両検出方法および車両検出プログラム |
| US9300954B2 (en) * | 2012-09-21 | 2016-03-29 | Tadano Ltd. | Surrounding information-obtaining device for working vehicle |
| JP5643272B2 (ja) * | 2012-09-21 | 2014-12-17 | 株式会社小松製作所 | 作業車両用周辺監視システム及び作業車両 |
| JP5924227B2 (ja) * | 2012-10-16 | 2016-05-25 | 株式会社デンソー | 車載カメラの取り付け誤差検出装置 |
| JP6072064B2 (ja) | 2012-11-08 | 2017-02-01 | 日立建機株式会社 | 自走式産業機械の画像処理装置および自走式産業機械の画像処理方法 |
| WO2014189009A1 (ja) * | 2013-05-21 | 2014-11-27 | 株式会社タダノ | カメラ姿勢検出装置と作業領域線表示装置 |
| CN103818828B (zh) * | 2014-03-05 | 2015-12-09 | 上海振华重工电气有限公司 | 集装箱起重机吊具对箱引导系统 |
| JP6260424B2 (ja) * | 2014-04-16 | 2018-01-17 | 株式会社デンソー | 車載カメラの取り付け誤差検出装置 |
| KR101579100B1 (ko) * | 2014-06-10 | 2015-12-22 | 엘지전자 주식회사 | 차량용 어라운드뷰 제공 장치 및 이를 구비한 차량 |
| JP6507501B2 (ja) | 2014-07-01 | 2019-05-08 | 株式会社タダノ | クレーン車の障害物報知システム |
| JP6458439B2 (ja) * | 2014-10-09 | 2019-01-30 | 株式会社デンソー | 車載カメラ較正装置、画像生成装置、車載カメラ較正方法、画像生成方法 |
| EP3385457A4 (en) * | 2015-11-30 | 2019-03-13 | Sumitomo Heavy Industries, Ltd. | PERIPHERAL MONITORING SYSTEM FOR A WORK MACHINE |
| KR101949358B1 (ko) * | 2016-04-04 | 2019-02-18 | 엘지전자 주식회사 | 차량용 어라운드뷰 제공 장치 및 이를 구비한 차량 |
| CN105806563A (zh) * | 2016-05-17 | 2016-07-27 | 福建工程学院 | 石材矿山叉装车智能辅助作业装置及方法 |
| KR102386846B1 (ko) * | 2016-07-05 | 2022-04-13 | 스미토모 겐키 가부시키가이샤 | 쇼벨 |
-
2017
- 2017-03-10 JP JP2017046830A patent/JP6794879B2/ja active Active
-
2018
- 2018-03-09 EP EP18763563.6A patent/EP3595298B1/en active Active
- 2018-03-09 CN CN201880015560.0A patent/CN110383831B/zh active Active
- 2018-03-09 WO PCT/JP2018/009293 patent/WO2018164273A1/ja not_active Ceased
- 2018-03-09 US US16/488,070 patent/US11120558B2/en active Active
Also Published As
| Publication number | Publication date |
|---|---|
| WO2018164273A1 (ja) | 2018-09-13 |
| EP3595298B1 (en) | 2024-12-18 |
| CN110383831A (zh) | 2019-10-25 |
| CN110383831B (zh) | 2021-01-22 |
| EP3595298A4 (en) | 2020-12-30 |
| JP2018152685A (ja) | 2018-09-27 |
| US11120558B2 (en) | 2021-09-14 |
| EP3595298A1 (en) | 2020-01-15 |
| US20200250831A1 (en) | 2020-08-06 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110383831B (zh) | 作业车辆用的人员检测系统和具备该系统的作业车辆 | |
| JP6390065B2 (ja) | クレーン | |
| US10323386B2 (en) | Surroundings monitoring system for work machine | |
| CN110023711B (zh) | 起重机 | |
| JP6342705B2 (ja) | 作業機用ブーム衝突回避装置 | |
| JP6934077B2 (ja) | ショベル | |
| JP6389087B2 (ja) | 作業機用ブーム衝突回避装置 | |
| JP6897075B2 (ja) | 過巻検出装置 | |
| JP6507501B2 (ja) | クレーン車の障害物報知システム | |
| JP2016115305A (ja) | 物体検出装置、物体検出システム、物体検出方法及びプログラム | |
| JP2017101419A (ja) | 作業機械用周辺監視システム | |
| CN111954637A (zh) | 起重车 | |
| JP6343189B2 (ja) | クレーン車の障害物報知システム | |
| US20200334474A1 (en) | Image processing device and image processing method | |
| JP2019142679A (ja) | 吊荷監視装置 | |
| JP2016013888A (ja) | クレーン車の障害物報知システム | |
| JP2016013890A (ja) | クレーン車の障害物報知システム | |
| EP4036047B1 (en) | Crane information display system | |
| JP2021075359A (ja) | ブームを有する作業車両の周囲監視装置 | |
| JP2023003182A (ja) | クレーン | |
| WO2023037936A1 (ja) | 作業車両 | |
| WO2020256101A1 (ja) | 画像システムおよび画像システムを備える作業車両 | |
| JP7484609B2 (ja) | クレーン走行支援装置 | |
| JP2019014584A (ja) | クレーン車 | |
| WO2024262519A1 (ja) | クレーン装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20200116 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20200616 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20200807 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20201013 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20201026 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 6794879 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |