JP3233367U - Automatic tray transfer device - Google Patents
Automatic tray transfer device Download PDFInfo
- Publication number
- JP3233367U JP3233367U JP2021001136U JP2021001136U JP3233367U JP 3233367 U JP3233367 U JP 3233367U JP 2021001136 U JP2021001136 U JP 2021001136U JP 2021001136 U JP2021001136 U JP 2021001136U JP 3233367 U JP3233367 U JP 3233367U
- Authority
- JP
- Japan
- Prior art keywords
- automatic
- lift
- drive
- tray transfer
- pedestal
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
- 238000012546 transfer Methods 0.000 title claims abstract description 51
- 230000003028 elevating effect Effects 0.000 claims abstract description 31
- 230000004308 accommodation Effects 0.000 claims abstract description 11
- NJPPVKZQTLUDBO-UHFFFAOYSA-N novaluron Chemical compound C1=C(Cl)C(OC(F)(F)C(OC(F)(F)F)F)=CC=C1NC(=O)NC(=O)C1=C(F)C=CC=C1F NJPPVKZQTLUDBO-UHFFFAOYSA-N 0.000 claims description 42
- 230000006698 induction Effects 0.000 claims description 22
- 230000007423 decrease Effects 0.000 claims description 3
- 238000010586 diagram Methods 0.000 abstract description 8
- 230000032258 transport Effects 0.000 description 29
- 238000000034 method Methods 0.000 description 9
- 230000008569 process Effects 0.000 description 8
- 238000004891 communication Methods 0.000 description 3
- 239000003638 chemical reducing agent Substances 0.000 description 2
- 230000005484 gravity Effects 0.000 description 2
- 230000001965 increasing effect Effects 0.000 description 2
- 239000000463 material Substances 0.000 description 2
- 230000001360 synchronised effect Effects 0.000 description 2
- 229910000831 Steel Inorganic materials 0.000 description 1
- 238000013473 artificial intelligence Methods 0.000 description 1
- 230000008859 change Effects 0.000 description 1
- 230000007812 deficiency Effects 0.000 description 1
- 238000013461 design Methods 0.000 description 1
- 238000011161 development Methods 0.000 description 1
- 238000005516 engineering process Methods 0.000 description 1
- 230000007613 environmental effect Effects 0.000 description 1
- 239000002184 metal Substances 0.000 description 1
- 239000010959 steel Substances 0.000 description 1
- 239000013585 weight reducing agent Substances 0.000 description 1
Images


Landscapes
- Forklifts And Lifting Vehicles (AREA)
Abstract
【課題】回転半径が小さく、現場環境に適応しやすい、自動トレー搬送装置を提供する。【解決手段】収容溝120が設けられる車体110を備える自動誘導搬送車と、収容溝に設けられかつフォークリフト装置上に設けられ、移動式駆動装置及び昇降駆動装置が備えられる自動積み下ろし装置200と、前記自動積み下ろし装置を地面上に置く又は地面から離すように構成されるフォークリフト装置と、を備える。前記移動式駆動装置は、前記自動積み下ろし装置が地面上に置かれるときに、前記自動積み下ろし装置を駆動して前記自動誘導搬送車に対して前記収容溝の外に突き出す又は収容溝内に格納するように構成され、前記昇降駆動装置は、前記自動積み下ろし装置を駆動してトレーを昇降させるように構成される。自動積み下ろし装置は、独立した移動式駆動装置と昇降駆動装置を搭載し、車体に対する相対移動を実現し、車体全体にトレーを搭載できる。【選択図】図1PROBLEM TO BE SOLVED: To provide an automatic tray transfer device having a small turning radius and easily adapting to a field environment. An automatic guided vehicle having a vehicle body 110 provided with an accommodation groove 120, and an automatic loading / unloading device 200 provided in the accommodation groove and provided on a forklift device and provided with a mobile drive device and an elevating drive device. It comprises a forklift device configured to place or remove the automatic loading / unloading device on or off the ground. When the automatic unloading device is placed on the ground, the mobile driving device drives the automatic unloading device so as to protrude out of the accommodating groove or store it in the accommodating groove with respect to the automatic guided transport vehicle. The elevating drive device is configured to drive the automatic loading / unloading device to elevate and lower the tray. The automatic loading / unloading device is equipped with an independent mobile drive device and an elevating drive device, realizes relative movement with respect to the vehicle body, and can mount a tray on the entire vehicle body. [Selection diagram] Fig. 1
Description
本出願は、搬送装置の技術分野に関し、特に、自動トレー搬送装置に関する。 The present application relates to the technical field of a transfer device, and particularly to an automatic tray transfer device.
科学技術の発展と進歩に伴い、ますます自動化されているが、トレー商品の搬送は依然としてフォークリフトの手動操作に大きく依存している。既存のトレーを運ぶために使用される無人搬送車(AGV)の多くは、電動フォークリフトで改造されたものであり、構造が冗長でコストも高い。また、現在のトレーAGVの多くは、車体とシェーパーの2つの部品で構成され、全長が長く、回転半径が大きいため、使用場所に対する環境要件が高い。 With the development and progress of science and technology, it is becoming more and more automated, but the transportation of tray goods still relies heavily on the manual operation of forklifts. Many of the automated guided vehicles (AGVs) used to carry existing trays have been modified with electric forklifts, which are redundant in structure and costly. In addition, most of the current tray AGVs are composed of two parts, a car body and a shaper, and have a long overall length and a large turning radius, so that environmental requirements for the place of use are high.
一方、AGVの使用が増えていることにもかかわらず、ほとんどのAGVは特別なラックとともに使用する必要があり、標準のトレーを運ぶことができない。さらに、既存のトレーAGV構造は、一般に、手動トレーフォークリフトの設計を参照して設計されたものであり、重心が高くて歩行の安定性が悪い。 On the other hand, despite the increasing use of AGVs, most AGVs need to be used with special racks and cannot carry standard trays. In addition, existing tray AGV structures are generally designed with reference to the design of manual tray forklifts, which have a high center of gravity and poor walking stability.
本出願の目的は、従来技術の欠陥を克服し、自動トレー搬送装置を提供する。 An object of the present application is to overcome the deficiencies of the prior art and provide an automatic tray transfer device.
本開示による実施形態の第一方面によれば、自動トレー搬送装置が提供される。該自動トレー搬送装置は、
収容溝が設けられる車体を備える自動誘導搬送車と、
収容溝に設けられかつフォークリフト装置上に設けられ、移動式駆動装置及び昇降駆動装置が備えられる自動積み下ろし装置と、前記自動積み下ろし装置を地面上に置く又は地面から離すように構成されるフォークリフト装置と、
を備え、
前記移動式駆動装置は、前記自動積み下ろし装置が地面上に置かれるときに、前記自動積み下ろし装置を駆動して前記自動誘導搬送車に対して前記収容溝の外に突き出す又は収容溝内に格納するように構成され、前記昇降駆動装置は、前記自動積み下ろし装置を駆動してトレーを昇降させるように構成される。
According to the first aspect of the embodiment according to the present disclosure, an automatic tray transfer device is provided. The automatic tray transfer device is
An automatic induction transport vehicle equipped with a vehicle body provided with a storage groove, and
An automatic unloading device provided in a containment groove and on a forklift device and provided with a mobile drive device and an elevating drive device, and a forklift device configured to place the automatic unloading device on or off the ground. ,
With
When the automatic loading / unloading device is placed on the ground, the mobile driving device drives the automatic unloading device so as to protrude out of the accommodating groove or store it in the accommodating groove with respect to the automatic guided transport vehicle. The elevating drive device is configured to drive the automatic loading / unloading device to elevate and lower the tray.
前記自動積み下ろし装置には、台座、カバー、前記移動式駆動装置及び前記昇降駆動装置が設けられてもよい。
ここで、前記移動式駆動装置は、前記自動積み下ろし装置が地面上に置かれるときに、前記台座を駆動して前記自動誘導搬送車に対して前記収容溝の外に突き出す又は収容溝内に格納するように構成され、前記昇降駆動装置は、前記カバーを昇降させるように構成される。
The automatic loading / unloading device may be provided with a pedestal, a cover, the mobile drive device, and the elevating drive device.
Here, when the automatic loading / unloading device is placed on the ground, the mobile drive device drives the pedestal to protrude out of the accommodation groove or store in the accommodation groove with respect to the automatic guidance transport vehicle. The elevating drive device is configured to elevate and elevate the cover.
前記自動積み下ろし装置は、シザーリフト装置をさらに備え、前記シザーリフト装置がスライドレールを介して前記台座に配合し、前記カバーは前記シザーリフト装置に配置され、前記昇降駆動装置は、夾角が増減するように前記シザーリフト装置を駆動してスライドレールに沿って移動させるように構成されてもよい。 The automatic loading / unloading device further includes a scissor lift device, the scissor lift device is compounded in the pedestal via a slide rail, the cover is arranged in the scissor lift device, and the lift / elevating drive device increases / decreases the angle. As described above, the scissor lift device may be configured to be driven and moved along the slide rail.
前記移動式駆動装置は、駆動固定台座を備え、前記移動式駆動装置は、前記駆動固定台座によって前記台座に固定的に接続されてもよい。
ここで、前記移動式駆動装置は、駆動固定軸及び駆動フレームをさらに備え、前記駆動フレームは、前記駆動固定軸を介して前記駆動固定台座に可動式に接続され、前記駆動フレームの前端には主従動輪が可動式に接続され、前記駆動フレームの後端には第1のモーターが固定的に接続されてもよい。
The mobile drive device includes a drive fixed pedestal, and the mobile drive device may be fixedly connected to the pedestal by the drive fixed pedestal.
Here, the mobile drive device further includes a drive fixed shaft and a drive frame, and the drive frame is movably connected to the drive fixed pedestal via the drive fixed shaft, and is connected to the front end of the drive frame. The main-slave driving wheel may be movably connected, and the first motor may be fixedly connected to the rear end of the drive frame.
前記主従動輪には前記従動軸が可動式に接続され、前記従動軸には前記駆動フレームが可動式に接続され、前記従動軸にはアイドラーホイールが固定的に接続されてもよい。 The driven shaft may be movably connected to the main driven wheel, the drive frame may be movably connected to the driven shaft, and an idler wheel may be fixedly connected to the driven shaft.
前記第1のモーターの出力軸には、主同期ホイールが固定的に接続され、前記主同期ホイールは、同期ベルトを介して前記アイドラーホイールに接続されてもよい。 A main synchronization wheel may be fixedly connected to the output shaft of the first motor, and the main synchronization wheel may be connected to the idler wheel via a synchronization belt.
前記フォークリフト装置が、第2のモーター、フォークアーム部品、及びリフト/スイング部品を備え、前記台座はリフト/スイング部品上に配置され、前記第1のモーターは、作動中前記フォークアーム部品によってリフト/スイング部品を駆動して垂直方向で直進し、前記台座にはフランジが設けられ、前記台座は、前記フランジによって前記リフト/スイング部品上で支持されてもよい。 The forklift device comprises a second motor, a forkarm component, and a lift / swing component, the pedestal is placed on the lift / swing component, and the first motor is lifted / lifted by the forkarm component during operation. The swing component may be driven to travel straight in the vertical direction, the pedestal may be provided with a flange, and the pedestal may be supported on the lift / swing component by the flange.
前記リフト/スイング部品がリフト/スイング部材を備え、前記リフト/スイング部材の外側にはローラーが固定的に接続され、前記リフト/スイング部材の内部にはベアリングが可動式に接続され、前記リフティングスイング部材の内面にはフォークリフティング固定軸が可動式に接続されてもよい。 The lift / swing component includes a lift / swing member, a roller is fixedly connected to the outside of the lift / swing member, and a bearing is movably connected to the inside of the lift / swing member. A fork lifting fixed shaft may be movably connected to the inner surface of the member.
フォークアーム部品が主軸を備え、前記主軸にはマスタースイングアームが固定的に接続され、前記マスタースイングアームの下端の外側にはヒンジアームが固定的に接続されてもよい。 The fork arm component may include a main shaft, the master swing arm may be fixedly connected to the main shaft, and the hinge arm may be fixedly connected to the outside of the lower end of the master swing arm.
前記フォークアーム部品が回転ピンをさらに備え、前記ヒンジアームが前記回転ピンを介して前記リフティングスイング部材内のベアリングに可動式に接続されてもよい。 The fork arm component may further include a rotating pin, and the hinge arm may be movably connected to a bearing in the lifting swing member via the rotating pin.
前記ヒンジアームには2つのリフト/スイング部品が可動式に接続され、2つの前記リフト/スイング部品が前記ヒンジアームの同じ側に接続されてもよい。 Two lift / swing components may be movably connected to the hinge arm, and the two lift / swing components may be connected to the same side of the hinge arm.
前記台座の両端には、シザーリフト装置及び対応する昇降駆動装置が設けられてもよい。 A scissor lift device and a corresponding elevating drive device may be provided at both ends of the pedestal.
前記自動誘導搬送車が、前記車体上に開かれた2つの収容溝を備え、2つの収容溝のいずれも自動積み下ろし装置及びフォークリフト装置が備えられてもよい。 The automatic induction transport vehicle may include two accommodating grooves opened on the vehicle body, and both of the two accommodating grooves may be provided with an automatic loading / unloading device and a forklift device.
前記2つの収容溝の間の車体には、前記自動誘導搬送車に対して電力を提供する電池装置が設けられてもよい。 The vehicle body between the two accommodation grooves may be provided with a battery device that provides electric power to the automatic induction carrier.
前記自動トレー搬送装置は、コントローラをさらに備え、前記コントローラは、前記移動式駆動装置及び前記昇降駆動装置と通信可能に接続されてもよい。 The automatic tray transfer device may further include a controller, which may be communicably connected to the mobile drive device and the lift drive device.
前記自動誘導搬送車は、2次元コード測位コントローラ及び2次元コードリーダーを備えてもよい。 The automatic guidance carrier may include a two-dimensional code positioning controller and a two-dimensional code reader.
本出願による自動トレー搬送装置は、自動誘導搬送車、自動積み下ろし装置、及びフォークリフト装置によってトレーの自動搬送を実現する。プロセス全体が手動介入を必要としない。自動誘導搬送車を使用するため、構造を簡素化し、低価格である。また、自動積み下ろし装置には、独立した移動式駆動装置と昇降駆動装置が設けられており、自動誘導搬送車に対する相対移動を実現し、全長は短くて構造がコンパクトである。トレーを自動誘導搬送車で運ぶことができる。この結果、自動トレー搬送装置全体の回転半径が小さくて現場環境への適応性が高いため、狭い空間でのトレー搬送に使用できる。 The automatic tray transfer device according to the present application realizes automatic tray transfer by an automatic guidance transfer vehicle, an automatic loading / unloading device, and a forklift device. The entire process does not require manual intervention. Since it uses an automatic induction carrier, the structure is simplified and the price is low. Further, the automatic loading / unloading device is provided with an independent mobile drive device and an elevating drive device, which realizes relative movement with respect to the automatic guidance carrier, and has a short overall length and a compact structure. The tray can be carried by an automatic induction carrier. As a result, the radius of gyration of the entire automatic tray transfer device is small and the adaptability to the site environment is high, so that it can be used for tray transfer in a narrow space.
以下、本開示の実施形態の図面を参照しながら、実施形態の技術的解決策を明確かつ完全に説明する。記載された実施形態は、本開示の実施形態の一部に過ぎず、すべての実施形態ではない。本開示の実施形態に基づいて、当業者が創造的な作業なしに得られる他のすべての実施形態は、本実用新案の保護範囲に含まれる。 Hereinafter, the technical solution of the embodiment will be clearly and completely described with reference to the drawings of the embodiments of the present disclosure. The embodiments described are only a part of the embodiments of the present disclosure and not all embodiments. Based on the embodiments of the present disclosure, all other embodiments obtained by those skilled in the art without creative work are included in the scope of protection of the Utility Model.
本開示の実施形態において、方向指示(上、下、左、右、前、後…など)がある場合、方向指示は、特定の姿勢(添付図面に示す)の場合の部品の相対的な位置関係と移動条件を説明するために使用されるものであり、特定の姿勢が変化すると、該方向指示もそれに応じて変化する。 In the embodiments of the present disclosure, when there is a turn signal (up, down, left, right, front, back, etc.), the turn signal is the relative position of the part in a particular posture (shown in the accompanying drawings). It is used to describe relationships and movement conditions, and when a particular posture changes, the turn signals change accordingly.
また、本開示の実施形態において「第1」、「第2」等に係る記述がある場合、「第1」、「第2」等の記述は、説明目的でのみ使用され、相対的な重要性を指示するか暗示するか、又は示された技術的機能の数を暗黙的に示すと理解してはいけない。従って、「第1」及び「第2」で限定された特徴には、明示的又は暗黙的に少なくとも1つの特徴が含まれる場合がある。さらに、様々な実施形態間の技術的解決策は互いに組み合わせることができるが、それは当業者によって達成できることに基づかなければならない。技術的解決策の組み合わせが矛盾するか又は達成できない場合、そのような技術的解決策の組み合わせは存在しなく、本実用新案によって要求される保護の範囲内ではない。 Further, when there is a description relating to "first", "second", etc. in the embodiment of the present disclosure, the description of "first", "second", etc. is used only for explanatory purposes and is relatively important. It should not be understood to indicate or imply sex, or to imply the number of technical functions shown. Therefore, the features limited by the "first" and "second" may include at least one feature, either explicitly or implicitly. Moreover, technical solutions between the various embodiments can be combined with each other, but they must be based on what can be achieved by one of ordinary skill in the art. If the combination of technical solutions is inconsistent or unattainable, then such combination of technical solutions does not exist and is not within the scope of protection required by the Utility Model.
本出願は、自動トレー搬送装置100を提供する。該自動トレー搬送装置100は、収容溝120が設けられる車体110を備える自動誘導搬送車と、収容溝120に設けられかつフォークリフト装置300上に設けられ、移動式駆動装置210及び昇降駆動装置220が備えられる自動積み下ろし装置200と、前記自動積み下ろし装置200を地面上に置くまたは地面から離すように構成されるフォークリフト装置300と、を備える。前記自動積み下ろし装置200には、移動式駆動装置210と昇降駆動装置220が設けられる。前記移動式駆動装置210は、前記自動積み下ろし装置200が地面上に置かれるときに、前記自動積み下ろし装置200を駆動して前記自動誘導搬送車に対して前記収容溝120の外に突き出すまたは収容溝120内に格納するように構成され、前記昇降駆動装置220は、前記自動積み下ろし装置200を駆動してトレーを昇降させるように構成される。
The present application provides an automatic
自動積み下ろし装置200は、トレー及びトレー上の材料の自動積み下ろしを実現することができる。自動誘導搬送車は、自動積み下ろし装置200及び積み下ろし材料を輸送することができる。具体的には、図1〜図3に示すように、自動誘導搬送車は、車体110の両側に配置された複数の駆動輪111と、車体110に配置され複数の駆動輪111を駆動するための搬送車駆動装置112とをさらに備える。搬送車駆動装置112は、複数の駆動輪111を駆動して回転させ、それにより車体110を駆動することができる。車体110の両側に複数の駆動輪111を均一に配置することにより、輸送過程における構造全体の安定性を確保することができ、輸送される重量物による車体110の転倒の問題が発生することを防止する。同時に、構造全体に必要なカウンターウェイトを減らして、操作全体でエネルギーを効果的に使用できるようにする。自動誘導搬送車が走行しているとき、自動積み下ろし装置200は収容溝120内に配置される。輸送作業を行うとき、自動積み下ろし装置200は、フォークリフト装置300によって地上に配置され、自動積み下ろし装置200は、移動式駆動装置210によって自動誘導輸送場所に対する移動を実現し、車体110の収容溝120の外に突き出し、トレーの底部に伸びる。
The
この実施形態では、上記駆動輪111は、狭い空間での商品の輸送に適するように、様々な方向への回転を容易にし、輸送の柔軟性を向上させるユニバーサルホイールとして設置することができる。一実施形態では、自動誘導搬送車は、動作を支援するための4つのユニバーサルホイールを備える。また、搬送車駆動装置112は、車体110に設けられた駆動モーター、駆動モーターに接続される減速機とを備え、駆動輪111の回転軸が減速機の出力軸に接続されている。さらに、複数の駆動輪111及び対応する搬送車駆動装置112を一体型駆動ユニットとして配置することができ、複数のそのような駆動ユニットを車体110の両側に配置して、構造全体の駆動を容易にすることができる。また、本実施形態では、上記車体110は、板金フレーム又は鉄骨構造フレームから構成することができ、車体110の軽量化を確保すると同時に十分な強度と剛性を有することができる。
In this embodiment, the
上記実施形態では、車体110に収容溝120が設けられ、自動積み下ろし装置200が収容溝120内に配置され、自動積み下ろし装置200が車体110内に配置されて車体110の外側に突き出さない。これにより、省スペースであることだけでなく、構造全体の重量を軽減できる。また、上記収容溝120の上部開口部は、車体110の上部に配置されている。上記収容溝120の側面開口部は、車体110の側面に位置される。すなわち、上記収容溝120の上部は外部と連通し、フォークリフト装置300の持ち上げを容易にする。上記収容溝120の側面は外部と連通し、自動積み下ろし装置200の突き出しを容易にする。また、上記収容溝120は、車体110の上下を貫通する。上記フォークリフト装置300は、自動積み下ろし装置200を駆動してトレーを収容溝120の上部より上方に上げるか、又は収容溝120の下方に下げることができる。
In the above embodiment, the
図1から図2に示すように、2つの収容溝120の間の車体110には、無人搬送車に電力を供給する電池装置113を備える。自動積み下ろし装置200が自動誘導搬送車の頭の前に配置される解決策と比較して、車体110の中央にある電池装置113、すなわち電池部品は、容積がより大きくなっている。よって、自動誘導搬送車の耐久性が大幅に向上する。
As shown in FIGS. 1 to 2, the
図4から図6に示すように、自動積み下ろし装置200は、台座230、カバー240、移動式駆動装置210、及び昇降駆動装置220を備える。移動式駆動装置210は、自動積み下ろし装置200が地面に置かれると、台座230を駆動することにより自動積み下ろし装置200を自動誘導搬送車に対して収容溝120から突き出すか、又は収容溝120内に格納するように構成される。昇降駆動装置220は、カバー240を駆動して昇降させるように構成される。自動積み下ろし装置200は、シザーリフト装置250をさらに備える。シザーリフト装置250は、スライドレール260を介して台座230と配合する。カバー240は、シザーリフト装置250に設けられる。昇降駆動装置220は、夾角が増減するようにシザーリフト装置250を駆動してスライドレール260に沿って移動させるように構成される。
As shown in FIGS. 4 to 6, the automatic loading /
移動式駆動装置210は、駆動固定台座211を備える。移動式駆動装置210は、駆動固定台座211を介して台座230に固定的に接続され、これにより、移動式駆動装置210を台座230に固定的に接続する。移動式駆動装置210は、駆動固定軸212と駆動フレーム213をさらに備える。駆動フレーム213は、駆動固定軸212を介して駆動固定台座211に可動式に接続される。駆動フレーム213の前端には、主従動輪214が可動式に接続される。駆動フレーム213の後端には、第1のモーター215が固定的に接続され、よって第1のモーター215及び主駆動輪214は、駆動フレーム213を介して移動式駆動装置210に接続されることができる。一実施形態では、主従動輪214には従動軸216が可動式に接続され、従動軸216には駆動フレーム213が可動式に接続され、従動軸216にはアイドラーホイール217が固定的に接続される。よって、主従動輪は214には駆動フレーム213が可動式に接続される。その結果、駆動装置は、主駆動輪214を介して地面と接触することができる。
The
上記の実施形態では、第1のモーター215の出力軸には、同期ベルトを介してアイドラーホイール217に接続されている主同期ホイール218が固定的に接続される。これにより、第1のモーター215が主従動輪を駆動して回転させることができる。この結果、移動式駆動装置210は、地上を移動することができる。一実施形態では、台座230は、スライドレールストッパー270を備える。
In the above embodiment, the main
フォークリフト装置の具体的な構造は、図7を参照しながら以下に説明する。図7に示すように、フォークリフト装置300は、第2のモーター301、フォークアーム部品302、及びリフト/スイング部品303を備える。台座230がリフト/スイング部品303上に配置され、第1のモーター215は、稼働中フォークアーム部品302によってリフト/スイング部品303を垂直に移動させる。台座230はフランジを備え、台座230は、フランジを介してリフト/スイング部品303上で支持される。台座230は、フランジを介してフォークリフト装置300に接続され、自動積み下ろし装置200の最大移動距離は、スライドレールストッパー270によって制限される。
The specific structure of the forklift device will be described below with reference to FIG. As shown in FIG. 7, the
一実施形態では、リフト/スイング部品303は、リフト/スイング部材3031を備える。リフト/スイング部材3031の外面には、ローラー3032が固定的に接続される。リフト/スイング部材3031の内面には、ベアリング3033が可動式に接続される。リフト/スイング部材3031の内面には、フォーク固定軸3034が可動式に接続される。これにより、リフト/スイング部品303を車体110、自動積み下ろし装置200、及びヒンジアーム3035に接続することができ、フォークリフト装置300によって自動搬送装置における自動積み下ろし装置200を駆動して昇降させる。
In one embodiment, the lift /
本出願の一実施形態では、フォークアーム部品302は主軸3021を備える。主軸3021には、マスタースイングアーム3022が固定的に接続される。マスタースイングアーム3022の下端には、ヒンジアーム3035が固定的に接続される。よって、主軸3021とヒンジアーム3035が接続され、主軸3021が回転するとヒンジアーム3035が駆動されて動かせる。
In one embodiment of the present application, the
他の一実施形態では、フォークアーム部品302は、回転ピン3023をさらに備える。ヒンジアーム3035は、回転ピン3023を介してリフト/スイング部材3031内のベアリング3033に可動式に接続される。これにより、フォークアーム部品302とリフト/スイング部品303とが可動式に接続される。フォークアーム部品302が動くとき、リフト/スイング部品303が駆動されて回転させる。ヒンジアーム3035には、2つのリフト/スイング部品303が可動式に接続される。2つのリフト/スイング部品303は、ヒンジアーム3035の同じ側に接続される。その結果、リフト/スイング部品303は、ヒンジアーム3035及びフォーク調整装置とより安定的かつ確実に接続され、フォーク調整装置の作業効率が向上する。
In another embodiment, the
本出願による自動トレー搬送装置は、自動誘導搬送車、自動積み下ろし装置、及びフォークリフト装置によってトレーの自動搬送を実現する。プロセス全体が手動介入を必要としない。自動誘導搬送車を使用するため、構造を簡素化し、低価格である。また、自動積み下ろし装置には、独立した移動式駆動装置と昇降駆動装置が設けられており、自動誘導搬送車に対する相対移動を実現し、全長は短くて構造がコンパクトである。トレーを自動誘導搬送車で運ぶことができる。この結果、自動トレー搬送装置全体の回転半径が小さくて現場環境への適応性が高いため、狭い空間でのトレー搬送に使用できる。 The automatic tray transfer device according to the present application realizes automatic tray transfer by an automatic guidance transfer vehicle, an automatic loading / unloading device, and a forklift device. The entire process does not require manual intervention. Since it uses an automatic induction carrier, the structure is simplified and the price is low. Further, the automatic loading / unloading device is provided with an independent mobile drive device and an elevating drive device, which realizes relative movement with respect to the automatic guidance carrier, and has a short overall length and a compact structure. The tray can be carried by an automatic induction carrier. As a result, the radius of gyration of the entire automatic tray transfer device is small and the adaptability to the site environment is high, so that it can be used for tray transfer in a narrow space.
他の一実施形態では、台座230の両端には、シザーリフト装置250及び対応する昇降駆動装置220が設けられている。
In another embodiment,
図1に示すように、自動誘導搬送車は、車体110に設けられる2つの収容溝120を備える。2つの収容溝120には、それぞれ自動積み下ろし装置200及びフォークリフト装置300の両方が設けられている。フォークリフト装置300は、複数のリフト/スイング部品303及び複数のフォークアーム部品302を備え、同じ第2のモーター301が、複数のリフト/スイング部品303及び複数のフォークアーム部品302を駆動してもよい。
As shown in FIG. 1, the automatic induction transport vehicle includes two
上記の実施形態では、自動トレー搬送装置100は、コントローラをさらに備える。コントローラは、移動式駆動装置210及び昇降駆動装置220と通信可能に接続される。上記のコントローラを、リモートコントローラとして設置することができる。自動トレー搬送装置100全体は、オペレータによって手動でリモート制御することができる。また、上記のコントローラーは、自動搬送装置全体を完全に自律的に制御できる人工知能コントローラーとして設置することもできる。
In the above embodiment, the automatic
一実施形態では、自動誘導搬送車には、2次元コード測位コントローラ及び2次元コードリーダーが設けられている。二次元コード測位コントローラは、マイクロプロセッサ、エンコーダ、通信インターフェースで構成されている。該マイクロプロセッサは、エンコーダに接続されて移動ロボットの動作速度を検出する。該マイクロプロセッサは、通信インターフェースを介して二次元コードリーダーに接続され、2次元コードナビゲーションベルトの情報を収集し、移動ロボットの正確な測位機能を実現する。2次元コードリーダーは無人搬送車に搭載されている。通信インターフェースは、例えば、ネットワークインターフェース、USBインターフェース、又は他のインターフェースである。2次元コードリーダーは、ネットワークインターフェース、USBインターフェース、又は他のインターフェースを備えるカメラデバイスである。自動トレー搬送装置100は、2次元コードナビゲーション方法を採用した自動誘導搬送車を備え、より高いナビゲーション精度を有する。
In one embodiment, the automatic guidance carrier is provided with a two-dimensional code positioning controller and a two-dimensional code reader. The two-dimensional code positioning controller consists of a microprocessor, an encoder, and a communication interface. The microprocessor is connected to an encoder to detect the operating speed of a mobile robot. The microprocessor is connected to a two-dimensional code reader via a communication interface, collects information on the two-dimensional code navigation belt, and realizes an accurate positioning function of the mobile robot. The two-dimensional code reader is mounted on an automatic guided vehicle. The communication interface is, for example, a network interface, a USB interface, or another interface. A two-dimensional code reader is a camera device that has a network interface, a USB interface, or other interface. The automatic
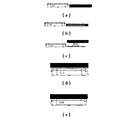
自動トレー搬送装置100による搬送、積み下ろしの工程は、以下のとおりである。図8(a)に示すように、自動誘導搬送車は、トレーから所定の距離を移動した後、停止して搬送を実行する。フォークリフト装置300によって自動積み下ろし装置200を地面に置く。図8(b)に示されるように、自動積み下ろし装置200は、移動式駆動装置210によって自動誘導搬送車に対する動きを実現し、車体110の収容溝120の外に突き出し、トレーの底部まで伸びる。図8(c)に示されるように、昇降駆動装置220は、自動積み下ろしを駆動してトレーを持ち上げる。図8(d)に示されるように、トレーが自動誘導搬送車の上に位置するまで、自動誘導搬送車が自動積み下ろし装置200に向いて移動する。図8(e)に示すように、昇降駆動装置220は、自動積み下ろし装置200を駆動してトレーを下げ、トレーを自動誘導搬送車の車体110の上部に配置する。フォークリフト装置300は、自動積み下ろし装置200を持ち上げる。自動誘導搬送車は、トレーを指定場所に輸送する。
The steps of transporting and unloading by the automatic
指定位置に到達すると、フォークリフト装置300は、自動積み下ろし装置200を地面に置き、昇降駆動装置220は、自動積み下ろし装置200を駆動してトレーを持ち上げ、自動誘導搬送車は、トレーの底部から完全に離れるまで自動積み下ろし装置200の反対方向に移動する。昇降駆動装置220は、自動積み下ろし装置200を駆動してトレーを下げて指定位置に配置する。移動式駆動装置210は、自動積み下ろし装置200を駆動して自動誘導搬送車に対して車体110内に引き戻し、フォークリフト装置300は、自動積み下ろし装置200を持ち上げる。
When the designated position is reached, the
自動積み下ろし装置200がシザーリフト装置250を備える場合、自動積み下ろし装置200がトレーの底部に移動した後、昇降駆動装置220は動作し、シザーリフト装置250の角度を増加させ、カバー240を持ち上げてトレーを持ち上げる。トレーが所定の位置に持ち上げられると、自動誘導搬送車は、自動積み下ろし装置200に対して移動し、トレーの下に完全に入った後、昇降駆動装置220は逆に作動し、シザーリフト装置250の角度を減少させ、カバー240が下げ、トレーは落下し最終的に車体110に配置される。フォークリフト装置300は、自動積み下ろし装置を持ち上げ、収容溝120に配置する。自動誘導搬送車は、自動積み下ろし装置200を駆動して、トレーを指定位置に搬送する。すなわち、図8(a)から(e)に示されるプロセスが実行される。
If the
トレーが指定位置に搬送されると、フォークリフト装置300は、自動積み下ろし装置200を地面に置き、昇降駆動装置220は動作し、シザーリフト装置250の角度を増加させ、カバー240が持ち上げられてトレーが車体110から持ち上げられて離れる。車体110は、搬送車駆動装置112によって移動され、トレーから移動される。昇降駆動装置220は逆に作動して、シザーリフト装置250の角度を減少させ、カバー240が下げ、トレーが地面まで下げる。センサーはカバー240が所定の位置に下げられたことを検出した後、自動積み下ろし装置200は、移動式駆動装置210を介して車体110の内側に戻り、フォークリフト装置300は、自動積み下ろし装置200を持ち上げて収容溝120に配置する。すなわち、図8(e)から(a)に示されるプロセスを実行し、その後、搬送プロセスが終了する。搬送プロセスではトレーは車体110の上部に配置されるため、重心が低くなり、歩行の安定性が向上する。
When the tray is transported to the designated position, the
本出願の好ましい具体的な実施形態及び実施例は、添付の図面を参照しながら上記で詳細に説明されたが、本出願は、上記の実施形態及び実施例に限定されず、当業者の知識の範囲内で、本出願の思想から逸脱することなく様々な変更が可能である。 Preferred specific embodiments and examples of the present application have been described in detail above with reference to the accompanying drawings, but the present application is not limited to the above embodiments and examples and will be knowledgeable by those skilled in the art. Within the scope of, various changes can be made without departing from the ideas of the present application.
符号は次の通りである。 The symbols are as follows.

前記フォークアーム部品が回転ピンをさらに備え、前記ヒンジアームが前記回転ピンを介して前記リフト/スイング部材内のベアリングに可動式に接続されてもよい。 The fork arm component may further include a rotating pin, and the hinge arm may be movably connected to a bearing in the lift / swing member via the rotating pin.
前記自動誘導搬送車が、前記車体上に設けられる2つの収容溝を備え、2つの収容溝のそれぞれには、自動積み下ろし装置及びフォークリフト装置が配置されてもよい。 The automatic guidance transport vehicle may include two accommodating grooves provided on the vehicle body, and an automatic loading / unloading device and a forklift device may be arranged in each of the two accommodating grooves.
Claims (16)
収容溝(120)に設けられかつフォークリフト装置(300)上に設けられ、移動式駆動装置(210)及び昇降駆動装置(220)が備えられる自動積み下ろし装置(200)と、前記自動積み下ろし装置(200)を地面上に置く又は地面から離すように構成されるフォークリフト装置(300)と、
を備え、
前記自動積み下ろし装置200には、移動式駆動装置(210)と昇降駆動装置が設けられ、前記移動式駆動装置(210)は、前記自動積み下ろし装置(200)が地面上に置かれるときに、前記自動積み下ろし装置(200)を駆動して前記自動誘導搬送車に対して前記収容溝(120)の外に突き出す又は収容溝(120)内に格納するように構成され、前記昇降駆動装置(220)は、前記自動積み下ろし装置(200)を駆動してトレーを昇降させるように構成される
ことを特徴とする自動トレー搬送装置(100)。 An automatic induction carrier having a vehicle body (110) provided with a storage groove (120), and
An automatic unloading device (200) provided in the accommodating groove (120) and provided on the forklift device (300) and provided with a mobile drive device (210) and an elevating drive device (220), and the automatic unloading device (200). ) Is placed on or off the ground with a forklift device (300).
With
The automatic unloading device 200 is provided with a mobile drive device (210) and an elevating drive device, and the mobile drive device (210) is said to be said when the automatic unloading device (200) is placed on the ground. The elevating drive device (220) is configured to drive an automatic loading / unloading device (200) so as to protrude from the accommodating groove (120) or be stored in the accommodating groove (120) with respect to the automatic guided transport vehicle. Is an automatic tray transfer device (100), which is configured to drive the automatic loading / unloading device (200) to raise and lower the tray.
前記移動式駆動装置(210)は、前記自動積み下ろし装置(200)が地面上に置かれるときに、前記台座(230)を駆動して前記自動誘導搬送車に対して前記収容溝(120)の外に突き出す又は収容溝(120)内に格納するように構成され、前記昇降駆動装置(220)は、前記カバー(240)を昇降させるように構成される
請求項1に記載の自動トレー搬送装置(100)。 The automatic loading / unloading device (200) is provided with a pedestal (230), a cover (240), the mobile drive device (210), and the elevating drive device (220).
The mobile drive device (210) drives the pedestal (230) when the automatic loading / unloading device (200) is placed on the ground to provide the accommodation groove (120) with respect to the automatic guidance transport vehicle. The automatic tray transport device according to claim 1, wherein the elevating drive device (220) is configured to project out or be stored in a storage groove (120), and the cover (240) is configured to elevate the cover (240). (100).
請求項2に記載の自動トレー搬送装置(100)。 The automatic loading / unloading device (200) further includes a scissor lift device (250), the scissor lift device (250) is compounded with the pedestal (230) via a slide rail (260), and the cover (240) is Arranged in the scissor lift device (250), the elevating drive device (220) is configured to drive the scissor lift device (250) and move it along a slide rail (260) so that the angle of inclination increases or decreases. The automatic tray transfer device (100) according to claim 2.
前記移動式駆動装置(210)は、駆動固定軸(212)及び駆動フレーム(213)をさらに備え、前記駆動フレーム(213)は、前記駆動固定軸(212)を介して前記駆動固定台座(211)に可動式に接続され、前記駆動フレーム(213)の前端には主従動輪(214)が可動式に接続され、前記駆動フレーム(213)の後端には第1のモーター(215)が固定的に接続される
請求項3に記載の自動トレー搬送装置(100)。 The mobile drive device (210) includes a drive fixed pedestal (211), and the mobile drive device (210) is fixedly connected to the pedestal (230) by the drive fixed pedestal (211).
The mobile drive device (210) further includes a drive fixed shaft (212) and a drive frame (213), and the drive frame (213) is connected to the drive fixed pedestal (211) via the drive fixed shaft (212). ) Is movably connected, a main driven wheel (214) is movably connected to the front end of the drive frame (213), and a first motor (215) is fixed to the rear end of the drive frame (213). The automatic tray transfer device (100) according to claim 3, which is connected to the device.
請求項4に記載の自動トレー搬送装置(100)。 The driven shaft (216) is movably connected to the main driven wheel (214), the drive frame (213) is movably connected to the driven shaft (216), and the driven shaft (216) is movably connected. The automatic tray transfer device (100) according to claim 4, wherein the idler wheel (217) is fixedly connected.
請求項5に記載の自動トレー搬送装置(100)。 A main synchronization wheel (218) is fixedly connected to the output shaft of the first motor (215), and the main synchronization wheel (218) is connected to the idler wheel (217) via a synchronization belt. The automatic tray transfer device (100) according to claim 5.
請求項2に記載の自動トレー搬送装置(100)。 The forklift device (300) includes a second motor (301), a fork arm component (302), and a lift / swing component (303), and the pedestal (230) is placed on the lift / swing component (303). The first motor (215) is driven by the fork arm component (302) to travel straight in the vertical direction by the fork arm component (302), and the pedestal (230) is provided with a flange. The automatic tray transfer device (100) according to claim 2, wherein the pedestal (230) is supported on the lift / swing component (303) by the flange.
請求項7に記載の自動トレー搬送装置(100)。 The lift / swing component (303) includes a lift / swing member (3031), and a roller (3032) is fixedly connected to the outside of the lift / swing member (3031), and the lift / swing member (3031). The automatic tray transport device according to claim 7, wherein a bearing (3033) is movably connected to the inside of the lift / swing member (3031), and a fork fixing shaft (3034) is movably connected to the inner surface of the lift / swing member (3031). (100).
請求項8に記載の自動トレー搬送装置(100)。 The fork arm component (302) includes a spindle (3021), a master swing arm (3022) is fixedly connected to the spindle (3021), and a hinge arm (3021) is outside the lower end of the master swing arm (3022). The automatic tray transfer device (100) according to claim 8, wherein the 3035) is fixedly connected.
請求項9に記載の自動トレー搬送装置(100)。 The fork arm component (302) further comprises a rotating pin (3023), and the hinge arm (3035) is movable via the rotating pin (3023) to a bearing (3033) in the lift / swing member (3031). The automatic tray transfer device (100) according to claim 9, which is connected to the automatic tray transfer device (100).
請求項10に記載の自動トレー搬送装置(100)。 Claim that two lift / swing parts (303) are movably connected to the hinge arm (3035) and the two lift / swing parts (303) are connected to the same side of the hinge arm (3035). 10. The automatic tray transfer device (100) according to 10.
請求項1又は2に記載の自動トレー搬送装置(100)。 The automatic tray transfer device (100) according to claim 1 or 2, wherein a scissor lift device (250) and a corresponding elevating drive device (220) are provided at both ends of the pedestal (230).
請求項1又は2に記載の自動トレー搬送装置(100)。 The automatic induction transport vehicle includes two accommodation grooves (120) opened on the vehicle body (110), and both of the two accommodation grooves (120) have an automatic loading / unloading device (200) and a forklift device (300). The automatic tray transfer device (100) according to claim 1 or 2.
請求項8に記載の自動トレー搬送装置(100)。 The automatic tray transfer device according to claim 8, wherein a battery device (113) for supplying electric power to the automatic induction transfer vehicle is provided in a vehicle body (110) between the two accommodation grooves (120). (100).
請求項1又は2に記載の自動トレー搬送装置(100)。 The automatic tray transfer device (100) according to claim 1 or 2, further comprising a controller, wherein the controller is communicably connected to the mobile drive device (210) and the elevating drive device (220).
請求項1又は2に記載の自動トレー搬送装置(100)。 The automatic tray transfer device (100) according to claim 1 or 2, wherein the automatic guidance transfer vehicle includes a two-dimensional code positioning controller and a two-dimensional code reader.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202023099261.3U CN213862473U (en) | 2020-12-21 | 2020-12-21 | Automatic pallet handling equipment |
| CN202023099261.3 | 2020-12-21 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| JP3233367U true JP3233367U (en) | 2021-08-05 |
Family
ID=77057302
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2021001136U Expired - Fee Related JP3233367U (en) | 2020-12-21 | 2021-03-30 | Automatic tray transfer device |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP3233367U (en) |
| CN (1) | CN213862473U (en) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114906773A (en) * | 2022-06-06 | 2022-08-16 | 北京捷象灵越科技有限公司 | Forklift robot and working method |
| CN115258001A (en) * | 2022-08-30 | 2022-11-01 | 杭州海康机器人股份有限公司 | Conveying device and conveying method |
| JP2024502507A (en) * | 2020-12-31 | 2024-01-19 | 杭州海康机器人股▲ふん▼有限公司 | Conveyance device and cargo conveyance method |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113979375A (en) * | 2021-11-19 | 2022-01-28 | 广州风神汽车有限公司 | Automatic guiding transport vehicle for whole vehicle |
| CN115448219B (en) * | 2022-09-22 | 2025-11-11 | 广东塔斯克机器人有限公司 | Cargo handling system |
| CN115744744A (en) * | 2022-10-25 | 2023-03-07 | 广东塔斯克机器人有限公司 | Automatic guide tray transport and transportation car |
-
2020
- 2020-12-21 CN CN202023099261.3U patent/CN213862473U/en not_active Expired - Fee Related
-
2021
- 2021-03-30 JP JP2021001136U patent/JP3233367U/en not_active Expired - Fee Related
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2024502507A (en) * | 2020-12-31 | 2024-01-19 | 杭州海康机器人股▲ふん▼有限公司 | Conveyance device and cargo conveyance method |
| JP7678887B2 (en) | 2020-12-31 | 2025-05-16 | 杭州海康机器人股▲ふん▼有限公司 | Transport device and baggage transport method |
| CN114906773A (en) * | 2022-06-06 | 2022-08-16 | 北京捷象灵越科技有限公司 | Forklift robot and working method |
| CN115258001A (en) * | 2022-08-30 | 2022-11-01 | 杭州海康机器人股份有限公司 | Conveying device and conveying method |
Also Published As
| Publication number | Publication date |
|---|---|
| CN213862473U (en) | 2021-08-03 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP3842605B1 (en) | Intelligent parking lot and cluster transport robot thereof | |
| CN111320107B (en) | Automatic loading, unloading and transporting integrated carrying device, system and method | |
| CN213862473U (en) | Automatic pallet handling equipment | |
| CN105857116B (en) | The driving mechanism of homing guidance formula handling device | |
| CN105946548B (en) | Homing guidance formula handling device | |
| WO2016197610A1 (en) | Agv comb-type transfer robot | |
| WO2023103674A1 (en) | Agv forklift | |
| CN115108498B (en) | Control method and system of automatic stacking storage forklift robot system | |
| JP2020183149A (en) | Transport vehicle | |
| CN111673759A (en) | Intelligent logistics carrying robot | |
| CN217478994U (en) | AMR carrier with omnidirectional laser navigation cooperation | |
| CN113104770A (en) | Multifunctional AGV capable of avoiding obstacles and obstacle avoiding method thereof | |
| CN115123969B (en) | Automatic storage fork truck robot of stack | |
| CN217048860U (en) | Automatic lift AGV floor truck | |
| CN223254393U (en) | Loading and unloading robot capable of operating in gooseneck carriage | |
| CN210260981U (en) | Lifting device for be used for from navigation AGV dolly | |
| CN110254491B (en) | Auto parts conveyer that can seek way automatically | |
| CN112455713A (en) | AGV (automatic guided vehicle) for transporting airport luggage containers and transporting method | |
| CN212767901U (en) | Jacking formula track AGV dolly | |
| CN218778709U (en) | Railway box wagon loader | |
| CN212637738U (en) | AGV trolley with vertical lifting and horizontal conveying functions | |
| CN215556252U (en) | An AGV-based integrated intelligent storage robot for loading, unloading and palletizing | |
| CN214932956U (en) | Novel lifting structure AGV dolly | |
| CN214643589U (en) | Upper and lower part tooling system using intelligent omnidirectional mobile robot | |
| CN214028918U (en) | AGV intelligence protection dolly |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20210607 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 3233367 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| LAPS | Cancellation because of no payment of annual fees |