JP2020203781A - Thread winding device and automatic winder - Google Patents
Thread winding device and automatic winder Download PDFInfo
- Publication number
- JP2020203781A JP2020203781A JP2019113489A JP2019113489A JP2020203781A JP 2020203781 A JP2020203781 A JP 2020203781A JP 2019113489 A JP2019113489 A JP 2019113489A JP 2019113489 A JP2019113489 A JP 2019113489A JP 2020203781 A JP2020203781 A JP 2020203781A
- Authority
- JP
- Japan
- Prior art keywords
- package
- thread
- winding
- winds
- drum
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
- 238000004804 winding Methods 0.000 title claims abstract description 206
- 230000002093 peripheral effect Effects 0.000 claims abstract description 12
- 230000007423 decrease Effects 0.000 claims description 59
- 241000226585 Antennaria plantaginifolia Species 0.000 claims 1
- 230000007704 transition Effects 0.000 description 10
- 230000007547 defect Effects 0.000 description 5
- 230000005540 biological transmission Effects 0.000 description 4
- 230000005856 abnormality Effects 0.000 description 3
- 230000003247 decreasing effect Effects 0.000 description 3
- 238000001514 detection method Methods 0.000 description 3
- 230000002950 deficient Effects 0.000 description 2
- 238000010586 diagram Methods 0.000 description 2
- 230000001965 increasing effect Effects 0.000 description 2
- 238000000034 method Methods 0.000 description 2
- 230000002159 abnormal effect Effects 0.000 description 1
- 230000015572 biosynthetic process Effects 0.000 description 1
- 230000004397 blinking Effects 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 230000003028 elevating effect Effects 0.000 description 1
- 230000005484 gravity Effects 0.000 description 1
- 238000012544 monitoring process Methods 0.000 description 1
- 230000008961 swelling Effects 0.000 description 1
Images




Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H63/00—Warning or safety devices, e.g. automatic fault detectors, stop-motions ; Quality control of the package
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/02—Winding and traversing material on to reels, bobbins, tubes, or like package cores or formers
- B65H54/28—Traversing devices; Package-shaping arrangements
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H69/00—Methods of, or devices for, interconnecting successive lengths of material; Knot-tying devices ;Control of the correct working of the interconnecting device
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2701/00—Handled material; Storage means
- B65H2701/30—Handled filamentary material
- B65H2701/31—Textiles threads or artificial strands of filaments
Landscapes
- Engineering & Computer Science (AREA)
- Quality & Reliability (AREA)
- Winding Filamentary Materials (AREA)
- Filamentary Materials, Packages, And Safety Devices Therefor (AREA)
Abstract
Description
本発明は糸巻取装置及び自動ワインダに関する。 The present invention relates to a bobbin winder and an automatic winder.
例えば特許文献1には、パッケージの周面に接触する綾振ドラムを回転させることで、糸をトラバースさせながらパッケージに巻き取るように構成された糸巻取装置が開示されている。このような糸巻取装置では、例えば糸が綾振ドラムの裏側に回り込んだ状態で糸継ぎされた場合などに、糸が適切にトラバースされずに棒巻きが発生することがある。「棒巻き」とは、糸が正常にトラバースされずに、トラバース領域の一部に集中的に糸が巻かれることを言う。棒巻きが形成されたパッケージは不良品となるため、棒巻きが発生した場合はできる限り速やかにそのことを検出し、適切な措置を取ることが望ましい。
For example,
特許文献1の糸巻取装置は、パッケージの回転不良を検出できるように構成されているものの、棒巻きを検出するような構成については何ら開示されていない。また、糸巻取装置の中には、糸がトラバースされていることを検出するトラバースセンサや、糸の走行速度を検出する糸速センサ(糸長センサ)が搭載されたものがある。このようなセンサがあれば、棒巻きの発生を検出することも可能ではあるが、このようなセンサが搭載されていない糸巻取装置では、棒巻きの発生を検出することができなかった。
Although the thread winding device of
本発明は、以上の課題に鑑みてなされたものであり、トラバースセンサや糸速センサが搭載されていなくても棒巻きの発生を検出可能とすることを目的とする。 The present invention has been made in view of the above problems, and an object of the present invention is to be able to detect the occurrence of bar winding even if a traverse sensor or a yarn speed sensor is not mounted.
本発明に係る糸巻取装置は、パッケージの周面に接触するドラムを回転させながら糸をトラバースさせることで、前記パッケージに前記糸を巻き取るように構成された糸巻取装置であって、前記糸を単位回数トラバースさせる間に前記パッケージが何回転するかを示すパッケージワインド数に基づいて、前記糸がトラバース領域の一部に集中的に巻かれる棒巻きが発生しているか否かを判断する制御部を備えていることを特徴とする。 The thread winding device according to the present invention is a thread winding device configured to wind the thread around the package by traversing the thread while rotating a drum in contact with the peripheral surface of the package. Control to determine whether or not there is a bar winding in which the yarn is intensively wound in a part of the traverse region based on the number of package winds indicating how many rotations of the package during traversing the unit number of times. It is characterized by having a part.
このような糸巻取装置によれば、パッケージワインド数さえ求まれば、棒巻きの発生を検出することができる。パッケージワインド数は、パッケージの回転数及びドラムの回転数から算出することができ、これらの回転数を検出するためのセンサは糸巻取装置に搭載されているのが一般的である。したがって、トラバースセンサや糸速センサが搭載されていなくても棒巻きの発生を検出することができる。 According to such a bobbin winder, the occurrence of bar winding can be detected as long as the number of package winds is obtained. The number of package winds can be calculated from the number of rotations of the package and the number of rotations of the drum, and a sensor for detecting these rotation speeds is generally mounted on a bobbin winder. Therefore, it is possible to detect the occurrence of bar winding even if the traverse sensor or the yarn speed sensor is not mounted.
本発明において、前記制御部は、所定時間における前記パッケージワインド数の減少量に基づいて、前記棒巻きが発生しているか否かを判断するとよい。 In the present invention, the control unit may determine whether or not the bar winding has occurred based on the amount of decrease in the number of package winds in a predetermined time.
後で詳細に説明するが、棒巻きが発生するとパッケージワインド数が急激に変化する。このため、パッケージワインド数の減少量を棒巻き発生の判断基準として用いることで、棒巻きが発生しているか否かを適切に判断することができる。 As will be described in detail later, the number of package winds changes drastically when bar winding occurs. Therefore, by using the amount of decrease in the number of package winds as a criterion for determining the occurrence of bar winding, it is possible to appropriately determine whether or not bar winding has occurred.
本発明において、前記制御部は、前記所定時間における前記パッケージワインド数の減少量が所定の第1閾値を超えた場合に、前記棒巻きが発生していると判断するとよい。 In the present invention, the control unit may determine that the bar winding has occurred when the amount of decrease in the number of package winds in the predetermined time exceeds a predetermined first threshold value.
後で詳細に説明するが、この構成によれば、コーン巻パッケージの大径側で棒巻きが発生している場合に、棒巻きの発生を良好に検出することができる。 As will be described in detail later, according to this configuration, when bar winding occurs on the large diameter side of the cone winding package, the occurrence of bar winding can be satisfactorily detected.
本発明において、前記制御部は、前記所定時間における前記パッケージワインド数の減少量が所定の第2閾値を下回った場合に、前記棒巻きが発生していると判断するとよい。 In the present invention, the control unit may determine that the bar winding has occurred when the amount of decrease in the number of package winds in the predetermined time is less than the predetermined second threshold value.
後で詳細に説明するが、この構成によれば、コーン巻パッケージの小径側で棒巻きが発生している場合に、棒巻きの発生を良好に検出することができる。 As will be described in detail later, according to this configuration, when bar winding occurs on the small diameter side of the cone winding package, the occurrence of bar winding can be satisfactorily detected.
本発明において、前記制御部によって前記棒巻きが発生していると判断された場合に、オペレータにそのことを知らせるアラーム部が設けられているとよい。 In the present invention, it is preferable that an alarm unit is provided to notify the operator when the control unit determines that the bar winding has occurred.
このようなアラーム部を設けることで、オペレータが棒巻きの発生をすぐに把握することができるので、棒巻き発生時に迅速な対応が可能となる。 By providing such an alarm unit, the operator can immediately grasp the occurrence of bar winding, so that it is possible to quickly respond when bar winding occurs.
本発明において、前記制御部は、前記棒巻きが発生していると判断すると、前記パッケージへの前記糸の巻き取りを停止させるとよい。 In the present invention, when the control unit determines that the bar winding has occurred, it is preferable to stop the winding of the thread on the package.
この構成によれば、棒巻きの状態で糸がパッケージに巻かれる量を最小限にとどめることができる。 According to this configuration, the amount of yarn wound around the package in the rod-wound state can be minimized.
本発明において、軸方向において巻径が漸増又は漸減するコーン巻パッケージに前記糸を巻き取るとよい。 In the present invention, it is preferable to wind the yarn in a cone winding package in which the winding diameter gradually increases or decreases in the axial direction.
後で詳細に説明するように、パッケージがコーン巻パッケージの場合は、棒巻きが発生した際に、パッケージの回転数が特に急激に変化するので、棒巻きの発生を精度よく検出することができる。 As will be described in detail later, when the package is a cone-wound package, the rotation speed of the package changes particularly rapidly when bar winding occurs, so that the occurrence of bar winding can be detected accurately. ..
本発明において、前記ドラムは、前記糸をトラバースさせるための綾振溝が周面に形成された綾振ドラムであるとよい。 In the present invention, the drum may be a twill drum having a twill groove for traversing the thread formed on the peripheral surface.
綾振ドラムのワインド数はドラムの種類によって決まり、糸の巻き取り中に変化することがない。このため、綾振ドラムを使用する場合は、パッケージワインド数を簡単に求めることができる。 The number of winds of the Ayashin drum is determined by the type of drum and does not change during the winding of the thread. Therefore, when using a twill drum, the number of package winds can be easily obtained.
本発明に係る自動ワインダは、上記何れかの糸巻取装置が複数並べられていることを特徴とする。 The automatic winder according to the present invention is characterized in that a plurality of the above-mentioned thread winding devices are arranged.
このような自動ワインダによれば、各糸巻取装置にトラバースセンサや糸速センサが搭載されていなくても棒巻きの発生を検出することができる。 According to such an automatic winder, the occurrence of bar winding can be detected even if each thread winding device is not equipped with a traverse sensor or a thread speed sensor.
以下、本発明の実施形態の一例について、図面を参照しつつ説明する。 Hereinafter, an example of the embodiment of the present invention will be described with reference to the drawings.
(自動ワインダ)
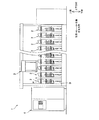
図1は、本実施形態に係る自動ワインダの概略構成図である。図1に示すように、自動ワインダ1は、一方向に配列された複数の巻取ユニット2(本発明の糸巻取装置に相当)と、複数の巻取ユニット2の配列方向に沿って走行自在に設けられた玉揚装置3と、機台制御装置4と、を備えている。以下では、図1に示すように、複数の巻取ユニット2の配列方向を左右方向とし、左右方向及び上下方向の両方に直交する方向(図1の紙面垂直方向)を前後方向とする。前後方向に関しては、図1の紙面垂直方向の手前側を前側、奥側を後側として説明を行う。
(Automatic winder)
FIG. 1 is a schematic configuration diagram of an automatic winder according to the present embodiment. As shown in FIG. 1, the
自動ワインダ1は、各々の巻取ユニット2において給糸ボビンBから解舒される糸Yを巻き取ってパッケージPを形成する。ある巻取ユニット2においてパッケージPが完成すると、玉揚装置3がその巻取ユニット2まで移動し、完成したパッケージPを回収して空の巻取管に交換する。機台制御装置4は、自動ワインダ1全体の制御を行っており、各巻取ユニット2や玉揚装置3に対して制御信号を発する。
The
(巻取ユニット)
図2は、巻取ユニット2の正面図である。巻取ユニット2は、給糸ボビンBから解舒される糸Yをトラバースさせながら巻取管Qに巻き取ってパッケージPを形成するものである。巻取ユニット2は、給糸ボビンBの糸Yを供給可能な状態で保持する給糸部10と、給糸部10に保持された給糸ボビンBから解舒された糸Yに対して様々な処理を行う糸処理部20と、糸処理部20で処理された糸Yを巻取管Qに巻き取ってパッケージPを形成する巻取部30と、これら各部10、20、30を制御するユニット制御部40(本発明の制御部に相当)と、を備える。給糸部10、糸処理部20、及び、巻取部30は、この順に、下から上へ並んで配置されている。
(Taking unit)
FIG. 2 is a front view of the take-
給糸部10は、給糸ボビンBを保持するボビン保持部11と、給糸ボビンBからの糸Yの解舒を補助する解舒補助装置12を有する。解舒補助装置12は、給糸ボビンBに上方から被せられる筒体13を有する。筒体13は、不図示の昇降装置によって昇降されるように構成されている。解舒補助装置12では、糸Yの解舒が進行するに従って、筒体13を下降させることで、解舒中の糸Yの膨らみ(バルーン)を規制し、糸Yの張力を安定させる。
The
巻取部30は、パッケージP(巻取管Q)を支持するクレードル31と、糸Yをトラバースさせる綾振ドラム32(本発明のドラムに相当)を有する。クレードル31は、パッケージPの両端部を回転自在に支持する。綾振ドラム32は、パッケージPの周面に接触しており、ドラムモータ33によって回転駆動される。綾振ドラム32の周面には綾振溝32aが形成されており、綾振溝32a内に糸Yが位置した状態で綾振ドラム32が回転することにより、糸Yがトラバースされる。綾振ドラム32がパッケージPに接触した状態で回転することで、パッケージPが従動回転し、綾振ドラム32によってトラバースされている糸YがパッケージPに巻き取られる。
The
巻取部30には、さらに、綾振ドラム32の回転数を検出するドラム回転センサ34と、パッケージPの回転数を検出するパッケージ回転センサ35とが設けられている。ドラム回転センサ34及びパッケージ回転センサ35は、例えば近接センサによって構成される。ドラム回転センサ34及びパッケージ回転センサ35による検出値は、ユニット制御部40に送信される。
The take-up
糸処理部20は、テンション付与装置21と、糸継装置22と、ヤーンクリアラ23と、下糸捕捉案内部材24と、上糸捕捉案内部材25と、を有する。
The
テンション付与装置21は、走行する糸Yに所定のテンションを付与するものである。図2では、一例として、いわゆるゲート式のテンション付与装置21を示している。ゲート式のテンション付与装置21では、複数の固定ゲート体21aと複数の可動ゲート体21bとが上下方向に交互に配置されている。そして、複数の可動ゲート体21bの水平方向の位置を調整することによって、固定ゲート体21aと可動ゲート体21bとの間を走行する糸Yに所定のテンションを付与する。
The
糸継装置22は、後述するヤーンクリアラ23により糸欠陥が検出されてカッター23aで糸Yが切断されたときや、巻取中に糸Yが切れたときや、給糸ボビンBの糸Yがなくなって給糸ボビンBを交換するときなどに、分断されている給糸ボビンB側(給糸部10側)の糸Y(下糸Y)とパッケージP側(巻取部30側)の糸Y(上糸Y)とを糸継ぎする。
In the
糸継装置22の下側と上側には、下糸Yを捕捉して糸継装置22へ案内する下糸捕捉案内部材24と、上糸Yを捕捉して糸継装置22へ案内する上糸捕捉案内部材25とがそれぞれ設けられている。下糸捕捉案内部材24は、軸24aを中心に回転可能であり、不図示のモータによって回転駆動されることで上下に旋回する。下糸捕捉案内部材24は、その先端部に下糸Yの糸端を吸引して捕捉する吸引部24bを有する。上糸捕捉案内部材25は、軸25aを中心に回転可能であり、不図示のモータによって回転駆動されることで上下に旋回する。上糸捕捉案内部材25は、その先端部に上糸Yの糸端を吸引して捕捉する吸引部25bを有する。
On the lower and upper sides of the
糸継装置22によって糸継ぎを行う場合、下糸捕捉案内部材24が下糸Yを糸継装置22に案内するとともに、上糸捕捉案内部材25が上糸Yを糸継装置22に案内する。具体的には、下糸捕捉案内部材24は、吸引部24bによって下糸Yの糸端を吸引捕捉した後、上方に旋回することで下糸Yを糸継装置22に案内する。また、上糸捕捉案内部材25は、まず上方に旋回し、吸引部25bをパッケージPと綾振ドラム32の接点近傍に位置させることで、吸引部25bによってパッケージPの表面に付着している上糸Yの糸端を吸引捕捉する。それから、上糸捕捉案内部材25は、上方から下方に旋回することで、上糸Yを糸継装置22に案内する。糸継装置22は、下糸捕捉案内部材24によって案内されてきた下糸Yの糸端と、上糸捕捉案内部材25によって案内されてきた上糸Yの糸端とを繋いで1本の糸Yにする。
When thread splicing is performed by the
ヤーンクリアラ23は、走行する糸Yの太さの情報を常時取得しており、糸Yの太さの情報に基づいて、糸Yに含まれる太さが一定以上に太い異常部分を糸欠陥として検出する。また、ヤーンクリアラ23にはカッター23aが付設されており、ヤーンクリアラ23で糸欠陥が検出されたときに、カッター23aが即座に糸Yを切断する。そして、糸欠陥の部分を除去してから、糸継装置22によって糸継ぎを行う。
The
巻取ユニット2には、アラーム部41が設けられている。アラーム部41は、巻取ユニット2にて異常が生じていることをオペレータに伝えるためのものである。本実施形態のアラーム部41は、光の点滅や点灯によって異常を伝えるランプ、及び/又は、音声によって異常を伝えるスピーカーによって構成されているが、アラーム部41の構成はこれらに限定されるものではない。
The take-up
(棒巻きの発生)
図3は、糸Yの巻取状態を示す模式的な側面図である。図3のa図は、糸Yが正常に巻き取られている状態を示し、図3のb図は、糸Yが棒巻きされている状態を示す。糸Yの巻き取りが正常に行われているときは、図3のa図に示すように、糸Yが綾振ドラム32に形成された綾振溝32a内を走行しつつパッケージPに巻き取られる。このため、糸Yは綾振ドラム32によって適切にトラバースされ、所望の形状のパッケージPが形成される。
(Occurrence of stick winding)
FIG. 3 is a schematic side view showing the winding state of the yarn Y. FIG. 3a shows a state in which the thread Y is normally wound, and FIG. 3b shows a state in which the thread Y is wound in a rod. When the thread Y is normally wound, as shown in FIG. 3A, the thread Y is wound around the package P while traveling in the
しかしながら、例えばパッケージPから垂れた糸Yが綾振ドラム32の裏側(下側)に回り込んだ状態で糸継ぎが行われた場合などには、図3のb図に示すように、糸Yが綾振溝32a内を走行せず、糸Yがトラバースされなくなる。そうすると、糸Yがトラバース領域の一部に集中的に巻かれる「棒巻き」が発生する。棒巻きが形成されたパッケージPは不良品となるため、棒巻きが発生した場合はできる限り速やかにそのことを検出し、適切な措置を取ることが望ましい。そこで、本実施形態では、以下の方法で棒巻きを検出している。
However, for example, when the thread Y is sewn around the back side (lower side) of the
(棒巻きの検出)
綾振ドラム32及びパッケージPのそれぞれに対して、ワインド数と呼ばれるパラメータがある。ワインド数とは、糸Yを単位回数トラバースさせる間、すなわち、糸Yをトラバース領域の一端から他端に1回移動させる間に、綾振ドラム32及びパッケージPがそれぞれ何回転するかを示す。綾振ドラム32のワインド数(以下、ドラムワインド数)は、綾振ドラム32の種類によって決まる一定値であり、糸Yを巻き取っている間に変化することはない。一方、パッケージPのワインド数(以下、パッケージワインド数)は、パッケージPの径が大きくなるにつれて減少する。
(Detection of bar winding)
For each of the
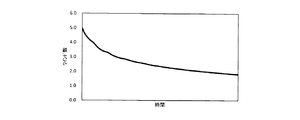
図4は、正常巻取時のパッケージワインド数の推移を示すグラフである。図5は、正常巻取時のパッケージワインド数の減少量の推移を示すグラフである。図5の「ワインド数減少量」とは、10秒間でパッケージワインド数がどれだけ減少したかを示す。糸Yが正常に巻き取られている場合は、時間の経過とともにパッケージPの径が大きくなり、綾振ドラム32が1回転する間のパッケージPの回転数が減少する。このため、図4に示すように、パッケージワインド数は徐々に減少する。パッケージワインド数の減少量は、図5に示すように、若干の増減を繰り返しながらも、長い時間で見ると徐々に小さくなる(減少ペースが遅くなる)。パッケージPの径が大きくなるにしたがって、パッケージPの径の増加ペースが遅くなるためである。
FIG. 4 is a graph showing the transition of the number of package winds at the time of normal winding. FIG. 5 is a graph showing the transition of the decrease in the number of package winds at the time of normal winding. The “amount of decrease in the number of winds” in FIG. 5 indicates how much the number of package winds decreased in 10 seconds. When the thread Y is normally wound, the diameter of the package P increases with the passage of time, and the number of rotations of the package P during one rotation of the
本実施形態では、ユニット制御部40が、パッケージワインド数の減少量に基づいて棒巻きが発生しているか否かを判断するように構成している。パッケージワインド数の減少量に基づいて棒巻きを検出できる原理について、パッケージPがコーン巻パッケージ(軸方向において巻径が漸増又は漸減する円錐台形状のパッケージ)である場合を例にして、図6及び図7を参照しつつ説明する。
In the present embodiment, the
図6は、糸Yの巻取状態を示す模式的な正面図である。図6のa図は、糸Yが正常に巻き取られている状態を示し、図6のb図は、コーン巻パッケージPの大径側の端部で棒巻きB1が発生している状態を示し、図6のc図は、コーン巻パッケージPの小径側の端部で棒巻きB2が発生している状態を示す。図7は、棒巻き発生時のパッケージワインド数の減少量の推移を示すグラフである。図7のa図は、コーン巻パッケージPの大径側で棒巻きが発生した場合を示し、図7のb図は、コーン巻パッケージPの小径側で棒巻きが発生した場合を示す。 FIG. 6 is a schematic front view showing the winding state of the yarn Y. FIG. 6A shows a state in which the thread Y is normally wound, and FIG. 6B shows a state in which bar winding B1 is generated at the end of the cone winding package P on the large diameter side. FIG. 6C of FIG. 6 shows a state in which the bar winding B2 is generated at the end portion of the cone winding package P on the small diameter side. FIG. 7 is a graph showing the transition of the amount of decrease in the number of package winds when bar winding occurs. FIG. 7a shows a case where bar winding occurs on the large diameter side of the cone winding package P, and FIG. 7b shows a case where bar winding occurs on the small diameter side of the cone winding package P.
図6のa図に示すように、糸Yが正常に巻き取られており、棒巻きが発生していない場合には、所望の形状のパッケージPが形成される。このとき、パッケージPは軸方向(トラバース方向)の概ね全域において綾振ドラム32と接触している。しかしながら、厳密には接圧が軸方向の位置によって異なっており、軸方向の中央領域Cにおいて接圧は最大となる。パッケージPは、綾振ドラム32の回転駆動力によって回転するが、その回転駆動力は接圧が最大となる中央領域Cを介してパッケージPに伝達される。つまり、パッケージPの回転数、さらにはパッケージワインド数は、中央領域Cの径Pdによって決まる。なお、接圧が最大となる中央領域Cは、パッケージPの重心位置との関係で決まるものであり、必ずしもパッケージPの軸方向の中心と正確に一致するわけではない。
As shown in FIG. 6a, when the yarn Y is normally wound and the rod winding is not generated, the package P having a desired shape is formed. At this time, the package P is in contact with the
パッケージワインド数をPw、ドラムワインド数をDw、綾振ドラム32の径をDdとすると、
Pw=Dw×Dd/Pd・・・式(1)
である。
さらに、パッケージPの回転数をPr、綾振ドラム32の回転数をDrとすると、パッケージPの周速と綾振ドラム32の周速とが等しいことから、
Pd×Pr=Dd×Dr・・・式(2)
である。
式(1)、(2)より、以下の式(3)が成り立つ。
Pw=Dw×Pr/Dr・・・式(3)
Assuming that the number of package winds is Pw, the number of drum winds is Dw, and the diameter of the
Pw = Dw × Dd / Pd ... Equation (1)
Is.
Further, assuming that the rotation speed of the package P is Pr and the rotation speed of the
Pd × Pr = Dd × Dr ... Equation (2)
Is.
From the equations (1) and (2), the following equation (3) holds.
Pw = Dw × Pr / Dr ... Equation (3)
既に説明したようにドラムワインド数Dwは、綾振ドラム32の種類によって決まる一定値であるから、パッケージPの回転数Prと綾振ドラム32の回転数Drが分かれば、パッケージワインド数Pwは式(3)より算出できる。既に説明したように、巻取ユニット2には、綾振ドラム32の回転数Drを検出するドラム回転センサ34と、パッケージPの回転数Prを検出するパッケージ回転センサ35とが設けられている。したがって、新たなセンサを追加しなくとも、パッケージワインド数Pwを算出することが可能である。ドラムワインド数Dwに関しては、ユニット制御部40が、オペレータによって入力された綾振ドラム32の種類に基づいてドラムワインド数Dwを取得する。
As described above, the drum wind number Dw is a constant value determined by the type of the
続けて、パッケージPに棒巻きが発生した場合に、パッケージワインド数がどのように変化するかについて説明する。図6のb図に示すように、コーン巻パッケージPの大径側の端部で棒巻きB1が発生した場合は、棒巻きB1の形成領域A1にて接圧が最大となる。このため、綾振ドラム32からパッケージPに回転駆動力を伝達する位置が、中央領域Cから大径側の形成領域A1に移動する。このように、回転駆動力の伝達位置が大径側に一気に移動することで、綾振ドラム32が1回転する間のパッケージPの回転数が急激に減少し、さらにはパッケージワインド数が急激に減少する。つまり、コーン巻パッケージPの大径側で棒巻きB1が発生した場合は、図7のa図に示すように、パッケージワインド数の減少量が急増する。
Next, how the number of package winds changes when a bar winding occurs in the package P will be described. As shown in FIG. 6b, when the bar winding B1 occurs at the end of the cone winding package P on the large diameter side, the contact pressure becomes maximum in the forming region A1 of the bar winding B1. Therefore, the position where the rotational driving force is transmitted from the
一方、図6のc図に示すように、コーン巻パッケージPの小径側の端部で棒巻きB2が発生した場合は、棒巻きB2の形成領域A2にて接圧が最大となる。このため、綾振ドラム32からパッケージPに回転駆動力を伝達する位置が、中央領域Cから小径側の形成領域A2に移動する。このように、回転駆動力の伝達位置が小径側に一気に移動することで、綾振ドラム32が1回転する間のパッケージPの回転数が急激に増加し、さらにはパッケージワインド数が急激に増加する。つまり、コーン巻パッケージPの小径側で棒巻きB2が発生した場合は、図7のb図に示すように、パッケージワインド数の減少量が急減する。なお、パッケージワインド数の減少量が負の値になっているということは、パッケージワインド数が増加していることを意味する。
On the other hand, as shown in FIG. 6C, when the bar winding B2 occurs at the end of the cone winding package P on the small diameter side, the contact pressure becomes maximum in the forming region A2 of the bar winding B2. Therefore, the position where the rotational driving force is transmitted from the
このようなパッケージワインド数の減少量の急激な増加又は減少は、パッケージPの回転数の急激な変化によるものである。したがって、パッケージPの回転数を監視するだけでも、棒巻きの検出が可能のように思える。しかしながら、リボン巻き(糸YがパッケージPの周面において同じ軌跡で巻き取られる現象)の発生を抑えるなどの目的で、糸Yの巻取中に綾振ドラム32の回転数が意図的に変更されることがある。綾振ドラム32の回転数が変更されると、それに伴ってパッケージPの回転数も変化する。したがって、棒巻きの検出のためにパッケージPの回転数だけを監視していると、綾振ドラム32の回転数を意図的に変更した場合にも棒巻きが発生していると誤検出するおそれがある。この点、綾振ドラム32の回転数も加味されるパッケージワインド数を監視すれば、棒巻きの検出精度を向上させることができる。
Such a rapid increase or decrease in the amount of decrease in the number of package winds is due to a rapid change in the number of revolutions of the package P. Therefore, it seems that the bar winding can be detected only by monitoring the rotation speed of the package P. However, the rotation speed of the
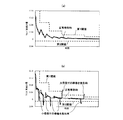
図8は、パッケージワインド数の減少量の推移及び閾値を示すグラフである。図8のa図は、正常巻取時のパッケージワインド数の減少量及び閾値を示し、図8のb図は、棒巻き発生時のパッケージワインド数の減少量及び閾値を示す。第1閾値は、パッケージワインド数の減少量が急増したこと、すなわち、コーン巻パッケージPの大径側で棒巻きが発生していることを検出するための閾値であり、正常巻取時のパッケージワインド数の減少量よりも大きな値が設定されている。一方、第2閾値は、パッケージワインド数の減少量が急減したこと、すなわち、コーン巻パッケージPの小径側で棒巻きが発生していることを検出するための閾値であり、正常巻取時のパッケージワインド数の減少量よりも小さな値が設定されている。図8に示す例では、第1閾値を概ね正常巻取時のパッケージワインド数の減少量の推移に沿って複数段階に設定し、第2閾値を一定値としている。第1閾値及び第2閾値は、糸番手などを考慮して事前に決定した値が記憶されているが、オペレータによって設定できるように構成してもよい。ユニット制御部40は、第1閾値及び第2閾値を記憶する。
FIG. 8 is a graph showing the transition of the decrease in the number of package winds and the threshold value. FIG. 8a shows the amount of decrease and the threshold value of the number of package winds at the time of normal winding, and FIG. 8b shows the amount of decrease and the threshold value of the number of package winds at the time of bar winding. The first threshold value is a threshold value for detecting that the amount of decrease in the number of package winds has increased sharply, that is, that bar winding has occurred on the large diameter side of the cone winding package P, and the package at the time of normal winding. A value larger than the amount of decrease in the number of winds is set. On the other hand, the second threshold value is a threshold value for detecting that the amount of decrease in the number of package winds has decreased sharply, that is, that bar winding has occurred on the small diameter side of the cone winding package P, and is a threshold value at the time of normal winding. A value smaller than the amount of decrease in the number of package winds is set. In the example shown in FIG. 8, the first threshold value is set to a plurality of stages according to the transition of the decrease amount of the number of package winds at the time of normal winding, and the second threshold value is set to a constant value. The first threshold value and the second threshold value store values determined in advance in consideration of the thread count and the like, but may be configured so that they can be set by the operator. The
ユニット制御部40は、所定の時間間隔(例えば2秒間隔)で、ドラム回転センサ34によって検出された綾振ドラム32の回転数Drと、パッケージ回転センサ35によって検出されたパッケージPの回転数Prと、ドラムワインド数Dwとに基づいて、パッケージワインド数Pwを求め、パッケージワインド数Pwの10秒間での減少量を算出する。そして、算出したパッケージワインド数Pwの減少量を、第1閾値及び第2閾値と比較する。パッケージワインド数Pwの減少量が第1閾値を超えている場合は、コーン巻パッケージPの大径側で棒巻きが発生していると判断し、アラーム部41を作動させ、糸Yの巻き取りを停止させる。パッケージワインド数Pwの減少量が第2閾値を下回っている場合は、コーン巻パッケージPの小径側で棒巻きが発生していると判断し、アラーム部41を作動させ、糸Yの巻き取りを停止させる。パッケージワインド数Pwの減少量が、第2閾値以上第1閾値以下の場合は、糸Yが正常に巻き取られていると判断し、糸Yの巻き取りを継続する。
The
図8のb図に示すように、実際に第1閾値及び第2閾値を適用した場合、コーン巻パッケージPの小径側で発生した1回目の棒巻きを除いて、残り全ての棒巻きを検出することができた。もちろん、第2閾値をもう少し大きく設定すれば、1回目の棒巻きも検出可能であり、第1閾値及び第2閾値を適宜調整することで、棒巻きの検出精度を向上させることが可能である。また、本実施形態では、第1閾値を複数段階に設定し、第2閾値を一定値としているが、第1閾値及び第2閾値をどのように設定するかは自由である。例えば、第1閾値及び第2閾値を、正常巻取時のパッケージワインド数の減少量の推移に沿って徐々に減少する設定としてもよい。 As shown in FIG. 8b, when the first threshold value and the second threshold value are actually applied, all the remaining bar windings are detected except for the first bar winding generated on the small diameter side of the cone winding package P. We were able to. Of course, if the second threshold value is set a little larger, the first bar winding can be detected, and by appropriately adjusting the first threshold value and the second threshold value, the bar winding detection accuracy can be improved. .. Further, in the present embodiment, the first threshold value is set in a plurality of stages and the second threshold value is set to a constant value, but how the first threshold value and the second threshold value are set is free. For example, the first threshold value and the second threshold value may be set to gradually decrease along with the transition of the decrease amount of the number of package winds at the time of normal winding.
ところで、コーン巻パッケージPの中央領域C(又はその近傍)で棒巻きが発生した場合は、コーン巻パッケージPの大径側及び小径側で棒巻きが発生したときのように、綾振ドラム32からパッケージPへの回転駆動力の伝達位置が一気に移動するということはない。このため、コーン巻パッケージPの中央領域Cで棒巻きが発生した場合は、図7に示すほど、パッケージワインド数の減少量に急激な変化は見られないので、棒巻きの検出が難しい。しかしながら、コーン巻パッケージPの場合、大径側又は小径側のどちらかに偏って棒巻きが発生することが多いため、仮に中央領域Cでの棒巻きの発生が検出できなくとも、それほど問題とはならない。
By the way, when bar winding occurs in the central region C (or its vicinity) of the cone winding package P, the
(効果)
本実施形態の巻取ユニット2は、パッケージワインド数に基づいて、棒巻きが発生しているか否かを判断するユニット制御部40を備えている。このような巻取ユニット2によれば、パッケージワインド数さえ求まれば、棒巻きの発生を検出することができる。パッケージワインド数は、綾振ドラム32の回転数及びパッケージPの回転数から算出することができ、これらの回転数を検出するためのセンサ(ドラム回転センサ34及びパッケージ回転センサ35)は巻取ユニット2に搭載されているのが一般的である。したがって、トラバースセンサや糸速センサが搭載されていなくても棒巻きの発生を検出することができる。
(effect)
The winding
本実施形態の巻取ユニット2では、ユニット制御部40は、所定時間(10秒間)におけるパッケージワインド数の減少量に基づいて、棒巻きが発生しているか否かを判断する。上述のように、棒巻きが発生するとパッケージワインド数が急激に変化する。このため、パッケージワインド数の減少量を棒巻き発生の判断基準として用いることで、棒巻きが発生しているか否かを適切に判断することができる。
In the winding
本実施形態の巻取ユニット2では、ユニット制御部40は、所定時間におけるパッケージワインド数の減少量が所定の第1閾値を超えた場合に、棒巻きが発生していると判断する。この構成によれば、コーン巻パッケージPの大径側で棒巻きが発生している場合に、棒巻きの発生を良好に検出することができる。
In the winding
本実施形態の巻取ユニット2では、ユニット制御部40は、所定時間におけるパッケージワインド数の減少量が所定の第2閾値を下回った場合に、棒巻きが発生していると判断する。この構成によれば、コーン巻パッケージPの小径側で棒巻きが発生している場合に、棒巻きの発生を良好に検出することができる。
In the winding
本実施形態の巻取ユニット2では、ユニット制御部40によって棒巻きが発生していると判断された場合に、オペレータにそのことを知らせるアラーム部41が設けられている。このようなアラーム部41を設けることで、オペレータが棒巻きの発生をすぐに把握することができるので、棒巻き発生時に迅速な対応が可能となる。
The winding
本実施形態の巻取ユニット2では、ユニット制御部40は、棒巻きが発生していると判断すると、パッケージPへの糸Yの巻き取りを停止させる。この構成によれば、棒巻きの状態で糸YがパッケージPに巻かれる量を最小限にとどめることができる。
In the winding
本実施形態の巻取ユニット2では、軸方向において巻径が漸増又は漸減するコーン巻パッケージPに糸Yを巻き取る。上述のように、パッケージPがコーン巻パッケージの場合は、棒巻きが発生した際に、綾振ドラム32からパッケージPへ回転駆動力を伝達する位置が変化することに伴い、パッケージPの回転数が特に急激に変化するので、棒巻きの発生を精度よく検出することができる。
In the winding
本実施形態の巻取ユニット2では、本発明のドラムが、糸Yをトラバースさせるための綾振溝32aが周面に形成された綾振ドラム32である。綾振ドラム32のワインド数はドラムの種類によって決まり、糸Yの巻き取り中に変化することがない。このため、綾振ドラム32を使用する場合は、パッケージワインド数を簡単に求めることができる。
In the winding
(他の実施形態)
上記実施形態に種々の変更を加えた変形例について説明する。
(Other embodiments)
A modified example in which various changes are made to the above embodiment will be described.
上記実施形態では、パッケージワインド数が10秒間でどれだけ減少したかを示す減少量に基づいて、棒巻きが発生しているか否かを判断するものとした。しかしながら、パッケージワインド数の減少量は10秒間の減少量に限定されず、適宜変更が可能である。また、棒巻きが発生しているか否かの判断に用いる数値は、パッケージワインド数の減少量に限定されず、パッケージワインド数そのものやパッケージワインド数の微分値など、パッケージワインド数に関する他の数値を用いてもよい。 In the above embodiment, it is determined whether or not bar winding has occurred based on the amount of decrease indicating how much the number of package winds has decreased in 10 seconds. However, the amount of decrease in the number of package winds is not limited to the amount of decrease for 10 seconds, and can be changed as appropriate. In addition, the numerical value used to determine whether or not bar winding has occurred is not limited to the amount of decrease in the number of package winds, and other numerical values related to the number of package winds such as the number of package winds themselves and the differential value of the number of package winds can be used. You may use it.
上記実施形態では、ユニット制御部40によって棒巻きが発生しているか否かの判断を行うものとした。しかしながら、棒巻きが発生しているか否かの判断主体はユニット制御部40に限定されず、例えば、機台制御装置4で行ってもよい。
In the above embodiment, the
上記実施形態では、棒巻きが発生していると判断された場合に、アラーム部41を作動させるとともに、巻取ユニット2による糸Yの巻き取りを停止するものとした。しかしながら、棒巻きが発生していると判断された場合に巻取ユニット2で実行される動作は、これに限定されるものではない。
In the above embodiment, when it is determined that the bar winding has occurred, the
上記実施形態では、パッケージPがコーン巻パッケージである場合について説明した。しかしながら、パッケージPがチーズ巻パッケージ(円筒状のパッケージ)に本発明を適用することも可能である。この場合、コーン巻パッケージの場合のように、回転駆動力の伝達の位置が変化しても径が急激に変化するわけではないので、コーン巻パッケージの場合よりも正常巻取時と棒巻き発生時とを区別するための閾値の設定値はシビアになるが、上記実施形態と同様の方法を採用することも可能である。 In the above embodiment, the case where the package P is a cone-wound package has been described. However, it is also possible for the package P to apply the present invention to a cheese-wrapped package (cylindrical package). In this case, as in the case of the cone winding package, the diameter does not change abruptly even if the position of transmission of the rotational driving force changes, so that normal winding and bar winding occur compared to the case of the cone winding package. Although the set value of the threshold value for distinguishing from time is severe, it is also possible to adopt the same method as in the above embodiment.
上記実施形態では、本発明のドラムが綾振ドラム32であるとした。しかしながら、例えば特開2019−59601号公報に記載されている巻取ユニットの構成を採用してもよい。この場合、上記公報のタッチローラが本発明のドラムとして機能し、ドラムとは別にアーム式のトラバース装置が設けられる。
In the above embodiment, the drum of the present invention is a
1:自動ワインダ
2:巻取ユニット(糸巻取装置)
32:綾振ドラム(ドラム)
32a:綾振溝
40:ユニット制御部(制御部)
41:アラーム部
Y:糸
P:パッケージ
1: Automatic winder 2: Winding unit (thread winding device)
32: Aya swing drum (drum)
32a: Twill groove 40: Unit control unit (control unit)
41: Alarm part Y: Thread P: Package
Claims (9)
前記糸を単位回数トラバースさせる間に前記パッケージが何回転するかを示すパッケージワインド数に基づいて、前記糸がトラバース領域の一部に集中的に巻かれる棒巻きが発生しているか否かを判断する制御部を備えていることを特徴とする糸巻取装置。 A thread winding device configured to wind the thread around the package by traversing the thread while rotating a drum that contacts the peripheral surface of the package.
Based on the number of package winds indicating how many rotations of the package are made while traversing the yarn a unit number of times, it is determined whether or not there is a bar winding in which the yarn is intensively wound in a part of the traverse region. A thread winding device characterized by being provided with a control unit.
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019113489A JP2020203781A (en) | 2019-06-19 | 2019-06-19 | Thread winding device and automatic winder |
| TR2020/07123A TR202007123A2 (en) | 2019-06-19 | 2020-05-07 | Yarn winding device and automatic winder. |
| CN202010483619.8A CN112110288A (en) | 2019-06-19 | 2020-06-01 | Yarn winding device and automatic winder |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019113489A JP2020203781A (en) | 2019-06-19 | 2019-06-19 | Thread winding device and automatic winder |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| JP2020203781A true JP2020203781A (en) | 2020-12-24 |
Family
ID=73799686
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2019113489A Pending JP2020203781A (en) | 2019-06-19 | 2019-06-19 | Thread winding device and automatic winder |
Country Status (3)
| Country | Link |
|---|---|
| JP (1) | JP2020203781A (en) |
| CN (1) | CN112110288A (en) |
| TR (1) | TR202007123A2 (en) |
Family Cites Families (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2004250139A (en) * | 2003-02-19 | 2004-09-09 | Murata Mach Ltd | Traverse method for bobbin winder |
| JP2006188342A (en) * | 2005-01-07 | 2006-07-20 | Murata Mach Ltd | Method of winding up elastic thread in automatic winder |
| JP2014019541A (en) * | 2012-07-18 | 2014-02-03 | Murata Mach Ltd | Yarn monitoring device and yarn winder |
| CN103010828B (en) * | 2012-10-30 | 2015-05-20 | 青岛宏大纺织机械有限责任公司 | Auxiliary anti-overlapping device and anti-overlapping method for randomly crossed and wound cheese windings |
| CN103010829B (en) * | 2012-12-24 | 2015-05-20 | 青岛宏大纺织机械有限责任公司 | Anti-stacking control device of cheese winder and anti-stacking method thereof |
| CN207293779U (en) * | 2017-09-18 | 2018-05-01 | 张家港扬子纺纱有限公司 | A kind of anti-yarn overlying device of winder |
-
2019
- 2019-06-19 JP JP2019113489A patent/JP2020203781A/en active Pending
-
2020
- 2020-05-07 TR TR2020/07123A patent/TR202007123A2/en unknown
- 2020-06-01 CN CN202010483619.8A patent/CN112110288A/en active Pending
Also Published As
| Publication number | Publication date |
|---|---|
| CN112110288A (en) | 2020-12-22 |
| TR202007123A2 (en) | 2021-06-21 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP5287992B2 (en) | Yarn winding device | |
| JP5884280B2 (en) | Yarn winding device and yarn winding method | |
| EP2690048B1 (en) | Yarn winding machine | |
| CN103569794A (en) | Yarn monitoring device and yarn winding machine | |
| JP2013241231A (en) | Yarn winding device and yarn winding method | |
| JP2010269915A (en) | Yarn winding device and alarm threshold value determining method for detecting rotation failure of package | |
| EP2990367B1 (en) | Yarn winding device | |
| JP2016016957A (en) | Yarn winder and yarn winding method | |
| JP6738184B2 (en) | Method and system for operating a complex system consisting of at least one ring spinning machine and at least one winder | |
| JP2010047406A (en) | Yarn winding device and automatic winder with the same | |
| CN102574655B (en) | Yarn winder | |
| JP2010042904A (en) | Yarn winding machine | |
| JP2013249189A (en) | Device of winding thread, method of winding thread, and system of winding thread | |
| JP2009227412A (en) | Yarn winder and yarn winding method | |
| JP2012250810A (en) | Thread winder | |
| CN103569780A (en) | Driving state detecting device, winding unit, winding machine, spinning unit, and spinning machine | |
| US6533211B2 (en) | Method of operating a textile machine for producing cheeses | |
| JP2012076884A (en) | Circuit board for yarn winding device, and yarn winding device | |
| JP4277227B2 (en) | Method for extracting winding package in automatic winder and automatic winder | |
| JP2007223779A (en) | Thread winding machine | |
| JP2009508783A (en) | Method of operating the working site of a textile machine that manufactures a twill roll package | |
| CN113044661B (en) | Yarn winding machine | |
| JP2014218314A (en) | Yarn winder | |
| JP2018002328A (en) | Textile machine | |
| JP2009214984A (en) | Method of manufacturing package, yarn winder and package |