JP2016027321A - Ultrasonic inspection method and probe installation jig - Google Patents
Ultrasonic inspection method and probe installation jig Download PDFInfo
- Publication number
- JP2016027321A JP2016027321A JP2015107518A JP2015107518A JP2016027321A JP 2016027321 A JP2016027321 A JP 2016027321A JP 2015107518 A JP2015107518 A JP 2015107518A JP 2015107518 A JP2015107518 A JP 2015107518A JP 2016027321 A JP2016027321 A JP 2016027321A
- Authority
- JP
- Japan
- Prior art keywords
- transmission
- reception probe
- probe
- reception
- wave
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images




Landscapes
- Investigating Or Analyzing Materials By The Use Of Ultrasonic Waves (AREA)
Abstract
Description
本発明は、超音波検査方法および探触子設置治具に関する。 The present invention relates to an ultrasonic inspection method and a probe installation jig.
従来、埋設物や遮蔽物のように視認困難な部位の腐食の検査において、超音波を検査対象に送信して、その反射波を受信して腐食を検査することが知られている。検査精度を向上するためには、十分な強度の超音波が伝播するように超音波の出力レベル(エネルギー)および指向性を向上する方法と、反射波のノイズなどを適切に除去して信号識別性を向上する方法がある。 2. Description of the Related Art Conventionally, in the inspection of corrosion of a portion that is difficult to visually recognize, such as an embedded object or a shield, it is known to transmit an ultrasonic wave to an inspection object and receive a reflected wave to inspect the corrosion. In order to improve inspection accuracy, a method to improve the output level (energy) and directivity of ultrasonic waves so that ultrasonic waves of sufficient intensity propagate, and signal identification by appropriately removing noise from reflected waves, etc. There are ways to improve the performance.
超音波の出力レベルおよび指向性を向上する方法としては、超音波を送受信する送受信探触子を大型化することが考えられる。 As a method for improving the output level and directivity of ultrasonic waves, it is conceivable to increase the size of a transmission / reception probe that transmits and receives ultrasonic waves.
信号識別性を向上する方法としては、相関処理によるパルス圧縮法が知られている。特許文献1に示す超音波診断装置には、生成したチャープ波に対して圧縮処理を行ってチャープ波圧縮信号を出力し、チャープ波圧縮信号に基づいてSH波を生成して被検体内に伝播させる技術が開示されている。この技術では、ノイズを低減するために、チャープ波は圧縮処理前にハミング窓関数処理される。
As a method for improving signal discrimination, a pulse compression method based on correlation processing is known. In the ultrasonic diagnostic apparatus disclosed in
ところで、超音波を検査対象に送信する際に、波形発生装置などによって制御して探触子に対して送信指示した電気信号波形と、実際に検査対象を伝播する伝播波形とに差異が生じる。そのため、実際の伝播波形と異なる電気信号波形を参照波形として計測波形との相関処理を行うと、整合性の精度に改善の余地がある。 By the way, when transmitting an ultrasonic wave to a test object, there is a difference between an electric signal waveform controlled by a waveform generator or the like and instructed to be transmitted to the probe, and a propagation waveform that actually propagates through the test object. Therefore, there is room for improvement in the accuracy of consistency when correlation processing with a measurement waveform is performed using an electric signal waveform different from the actual propagation waveform as a reference waveform.
本発明は、上記に鑑みてなされたものであって、相関処理における整合性の精度を改善して、検査精度がより向上した超音波検査方法および探触子設置治具を提案することを目的とする。 The present invention has been made in view of the above, and an object of the present invention is to propose an ultrasonic inspection method and a probe installation jig in which the accuracy of consistency in correlation processing is improved and the inspection accuracy is further improved. And
上述した課題を解決し、目的を達成するために、本発明に係る超音波検査方法では、
(1)計測用送受信探触子によって、検査対象に向けてSHガイド波を送信するSHガイド波送信ステップと、受信探触子によって、前記計測用送受信探触子から送信された前記SHガイド波を参照波形として受信する参照波受信ステップと、前記計測用送受信探触子によって、前記検査対象からの反射波を受信する反射波受信ステップと、前記受信探触子が受信した前記参照波形と、前記計測用送受信探触子が受信した前記反射波とに基づいて相関処理を行う相関処理ステップと、前記相関処理ステップによって得られた相関波形を出力する出力ステップと、を備えることを特徴とする。
In order to solve the above-mentioned problems and achieve the object, in the ultrasonic inspection method according to the present invention,
(1) An SH guide wave transmission step for transmitting an SH guide wave toward an inspection object by the measurement transmission / reception probe, and the SH guide wave transmitted from the measurement transmission / reception probe by the reception probe. A reference wave receiving step for receiving a reflected wave from the inspection object by the measurement transmission / reception probe, the reference waveform received by the reception probe, A correlation processing step of performing a correlation process based on the reflected wave received by the measurement transmission / reception probe; and an output step of outputting a correlation waveform obtained by the correlation processing step. .
(2)また、上記(1)の超音波検査方法において、前記計測用送受信探触子は、複数が前記SHガイド波の伝播方向に並列に配設されている、ことが好ましい。 (2) In the ultrasonic inspection method of (1) above, it is preferable that a plurality of the transmission / reception probes for measurement are arranged in parallel in the propagation direction of the SH guide wave.
(3)また、上記(1)または(2)の超音波検査方法は、前記計測用送受信探触子および前記受信探触子を、前記検査対象の前記SHガイド波の伝播方向と異なる方向に移動する移動ステップと、を備え、前記検査対象は、配管であり、前記SHガイド波の伝播方向は、前記配管の軸方向と一致し、前記検査対象の外周面の所定の場所において、前記SHガイド波送信ステップと前記参照波受信ステップと前記反射波受信ステップとを実施した後で、前記移動ステップを実施して前記検査対象の外周面を周方向に移動することを繰り返して、前記検査対象を全周に亘って検査する、ことが好ましい。 (3) Further, in the ultrasonic inspection method according to (1) or (2), the transmission / reception probe for measurement and the reception probe are placed in a direction different from a propagation direction of the SH guide wave to be inspected. A moving step that moves, wherein the inspection object is a pipe, and a propagation direction of the SH guide wave coincides with an axial direction of the pipe, and the SH at a predetermined location on the outer peripheral surface of the inspection object After performing the guide wave transmitting step, the reference wave receiving step, and the reflected wave receiving step, repeating the moving step to move the outer peripheral surface of the inspection object in the circumferential direction, the inspection object Is preferably inspected over the entire circumference.
(4)本発明に係る探触子設置治具は、上記(1)から(3)のいずれかの超音波検査方法に用いられ、前記計測用送受信探触子および前記受信探触子を前記検査対象に着脱自在に設置する探触子設置治具であって、前記計測用送受信探触子を、前記検査対象に押し付けた状態で支持する第1支持フレームと、前記受信探触子を、前記計測用送受信探触子から送信された前記SHガイド波の伝播方向に、前記検査対象に押し付けた状態で支持する第2支持フレームと、を備え、前記第2支持フレームは前記第1支持フレームに配設されており、前記検査対象からの反射波を受信した前記第1支持フレームに支持された前記計測用送受信探触子と、前記SHガイド波を参照波形として受信した前記第2支持フレームに支持された前記受信探触子との間隔は所定距離となる、ことを特徴とする。 (4) A probe installation jig according to the present invention is used in the ultrasonic inspection method according to any one of (1) to (3), and the transmission / reception probe for measurement and the reception probe are A probe installation jig that is detachably installed on an inspection target, the first support frame that supports the measurement transmission / reception probe in a state of being pressed against the inspection target, and the reception probe, A second support frame that supports the SH guide wave transmitted from the measurement transmission / reception probe in a state of being pressed against the inspection object, and the second support frame is the first support frame. The measurement transmitting / receiving probe supported by the first support frame that has received the reflected wave from the inspection object, and the second support frame that has received the SH guide wave as a reference waveform Supported by the receiving probe The spacing a predetermined distance, characterized in that.
(5)また、上記(4)の探触子設置治具において、前記第1支持フレームは、複数の前記計測用送受信探触子を、前記SHガイド波の伝播方向に並列に支持し、前記第2支持フレームは、前記受信探触子を、複数の前記計測用送受信探触子の中心線上に位置して支持する、ことが好ましい。 (5) In the probe installation jig according to (4), the first support frame supports a plurality of the transmission / reception probes for measurement in parallel in the propagation direction of the SH guide wave, The second support frame preferably supports the reception probe positioned on the center line of the plurality of measurement transmission / reception probes.
(6)また、上記(4)または(5)の探触子設置治具において、前記第2支持フレームは、前記第1支持フレームに対して摺動自在に配設されている、ことが好ましい。 (6) In the probe installation jig according to (4) or (5), it is preferable that the second support frame is slidably disposed with respect to the first support frame. .
本発明にかかる超音波検査方法は、計測用送受信探触子によって、検査対象に向けてSHガイド波を送信して、受信探触子が受信した参照波形と、計測用送受信探触子が受信した反射波とに基づいて相関処理を行う。これにより、実際に検査対象を伝播して受信探触子が受信した参照波形に基づいて相関処理するため、相関処理における整合性の精度が改善されて信号識別性が向上し、検査精度がより向上する、という効果を奏する。 In the ultrasonic inspection method according to the present invention, the SH transmission / reception probe transmits the SH guide wave toward the inspection target, and the reference waveform received by the reception probe and the measurement transmission / reception probe receive the reference waveform. Correlation processing is performed based on the reflected wave. As a result, the correlation processing is performed based on the reference waveform that is actually propagated through the inspection target and received by the reception probe, so that the accuracy of consistency in the correlation processing is improved, the signal identification is improved, and the inspection accuracy is further improved. There is an effect of improving.
また、探触子設置治具は、計測用送受信探触子および受信探触子を検査対象に着脱自在に設置し、検査対象からの反射波を受信した第1支持フレームに支持された計測用送受信探触子と、SHガイド波を参照波形として受信した第2支持フレームに支持された受信探触子との間隔は所定距離である。このため、超音波検査方法において、計測用送受信探触子および受信探触子を検査対象に容易に着脱できる、という効果を奏する。 Further, the probe installation jig is a measurement probe supported by a first support frame in which a measurement transmission / reception probe and a reception probe are detachably installed on an inspection target and a reflected wave from the inspection target is received. The interval between the transmission / reception probe and the reception probe supported by the second support frame that receives the SH guide wave as a reference waveform is a predetermined distance. Therefore, in the ultrasonic inspection method, there is an effect that the transmission / reception probe for measurement and the reception probe can be easily attached to and detached from the inspection target.
以下に、本発明にかかる超音波検査方法および探触子設置治具の実施形態を図面に基づいて詳細に説明する。なお、この実施形態によりこの発明が限定されるものではない。 Hereinafter, embodiments of an ultrasonic inspection method and a probe installation jig according to the present invention will be described in detail with reference to the drawings. In addition, this invention is not limited by this embodiment.
[第1実施形態]
図1ないし図16を参照して、第1実施形態について説明する。この実施形態は、超音波検査方法および探触子設置治具5に関する。超音波検査方法は、埋設物や遮蔽物のように視認困難な部位、例えば、図1に示すように、検査対象としての配管Pが、橋梁Bの橋桁B1下方に架設され(配管P1)、橋台B2を貫通(配管P2)して地面Gに埋設されている場合に、配管P2における腐食Xを検査する方法である。配管Pの中で、橋桁B1下方に架設されている配管P1は外部に露出しているので視認確認するものとし、地面Gに埋設されている箇所は今回の検査対象外であるものとする。そこで、この超音波検査方法は、配管Pの中で視認困難な配管P2について、超音波検査装置1と探触子設置治具5を使用して検査する。
[First Embodiment]
The first embodiment will be described with reference to FIGS. This embodiment relates to an ultrasonic inspection method and a
超音波検査装置1は、配管Pに取り付けられて、SHガイド波W1を送信して、その反射波W2を受信して腐食Xを検査するものである。具体的には、超音波検査装置1は、外部に露出している配管P1に取り付けられて、配管P1から配管P2に向かってSHガイド波W1を送信し、腐食Xにおいて反射して配管P2から配管P1に伝播する反射波W2を受信するものである。超音波検査装置1は、図1、図2に示すように、主として、計測用送受信探触子としての第1送受信探触子2および第2送受信探触子3と、受信探触子4と、送受信装置6と、保存・評価用PC(PC)8とを備えている。
The
第1送受信探触子2は、図1に示すように、配管P1の外周面に取り付けられて、配管P2の軸方向に向けてSHガイド波W1を送信し、配管P2からの反射波W2を受信する振動子を有するセンサである。この第1送受信探触子2は、直方体状の箱形に形成されている。振動子の大きさは、例えば、数10mm×数10mm程度のものとする。また、第1送受信探触子2は、振動子に高周波のパルス電圧を加えることにより振動を生じさせてSHガイド波W1を発生させて送信する。振動子に加える高周波のパルス電圧に関する情報は、後述する送受信装置6が生成する第1送受信探触子2に対する送信信号に含まれている。また、第1送受信探触子2は、振動子の振動により生じた振動を電気信号に変えて受信する。第1送受信探触子2は、後述する送受信装置6によって制御されている。第1送受信探触子2から送信されたSHガイド波W1は、配管P1、P2の周面を伝播して、腐食Xにおいて反射して反射波W2となり、その反射波W2を第1送受信探触子2が受信する。
As shown in FIG. 1, the first transmission /
ここで、SHガイド波W1は、非分散モードのチャープ波またはバースト波とする。このように第1送受信探触子2から送信されたSHガイド波W1は、配管P2の周方向の一部分を軸方向に伝播する。
Here, the SH guide wave W1 is a non-dispersion mode chirp wave or burst wave. Thus, the SH guide wave W1 transmitted from the first transmission /
第2送受信探触子3は、配管P1の外周面に、第1送受信探触子2と、SHガイド波W1の伝播方向に並列、すなわち、配管P1の軸方向に並列に取り付けられている。すなわち、第1送受信探触子2と第2送受信探触子3とは、配管P1の軸方向における同位置、かつ、配管P1の外周面に周方向に間隔を空けて取り付けられている。第2送受信探触子3は、第1送受信探触子2と同等の構成を有するセンサであり、第1送受信探触子2が送信するSHガイド波W1と同一(同周波数、同強度)のSHガイド波W1を同時に送信するように、後述する送受信装置6によって制御されている。
The second transmission /
ここで、第1送受信探触子2と第2送受信探触子3とは、「見かけの送受信探触子」を構成するものとする。見かけの送受信探触子を構成する第1送受信探触子2と第2送受信探触子3とは、並列に配設され、同一のSHガイド波W1を同時に送信する。このため、見かけの送受信探触子においては、2つのSHガイド波W1が合成されるので、第1送受信探触子2と第2送受信探触子3のそれぞれから出力されるSHガイド波W1や反射波W2に比べて出力レベルが増大する。また、見かけの送受信探触子は、第1送受信探触子2の図5における左端と第2送受信探触子3の図5における右端の間の配管P1の周方向の幅が「見かけの幅」となる。見かけの幅は、第1送受信探触子2と第2送受信探触子3のそれぞれの配管P1の周方向の幅より大きい。このため、見かけの送受信探触子は、第1送受信探触子2と第2送受信探触子3のそれぞれに比べて指向性が向上する。
Here, the first transmission /
なお、送受信探触子を並列に配置せず、単一で実際の幅を広げた送受信探触子を配管P1の外周面に取り付ける場合、単一で幅を広げた送受信探触子は、検査対象の外周面の影響を受けて、超音波の出力レベルおよび指向性が低下するおそれがある。 When a single transmitter / receiver probe having a wider width is attached to the outer peripheral surface of the pipe P1 without arranging the transmitter / receiver probes in parallel, the single transmitter / receiver probe having a wider width is inspected. There is a possibility that the output level and directivity of the ultrasonic wave may be lowered due to the influence of the outer peripheral surface of the object.
受信探触子4は、配管P1に取り付けられて、第1送受信探触子2および第2送受信探触子3から送信されたSHガイド波W1が配管P1を伝播したものを参照波W3(図6参照)として受信する振動子を有するセンサである。振動子の大きさは、例えば、数10mm×数10mm程度のものとする。また、受信探触子4は、振動子の振動により生じた振動を電気信号に変えて受信する。受信探触子4は、後述する送受信装置6によって制御されている。
The reception probe 4 is attached to the pipe P1, and the reference wave W3 (see FIG. 5) is obtained by transmitting the SH guide wave W1 transmitted from the first transmission /
このような第1送受信探触子2と、第2送受信探触子3と、受信探触子4とは、探触子設置治具5(図1参照)によって支持されている。探触子設置治具5は、超音波検査方法に用いられ、第1送受信探触子2および第2送受信探触子3と受信探触子4とを配管P1に着脱自在に設置するものである。探触子設置治具5は、図3、図4に示すように、主として、第1支持フレーム51と、第2支持フレーム52と、ハンドル53とを備えている。
The first transmission /
第1支持フレーム51は、図5に示すように、第1送受信探触子2および第2送受信探触子3を並列に、配管P1に押し付けた状態で支持するものである。第1支持フレーム51は、図3、図4に示すように、第1送受信探触子2および第2送受信探触子3(図4参照)を収容可能な箱形に形成されている。図5に示すように、この第1支持フレーム51に収容された第1送受信探触子2および第2送受信探触子3は、底面部が配管P1に押圧されて密着する。第1支持フレーム51は、図3、図4に示すように、対向する側板511同士を連結する連結アーム512を有している。具体的には、図5に示すように、略扇形の薄板で構成された対向する側板511の端部同士が、4本の連結アーム512で連結されている。この側板511の一辺(図中において底辺)は、配管P1の外周面に沿って湾曲している。
As shown in FIG. 5, the
下側の連結アーム512の下方(配管P1側)には、磁石513(図3、図5参照)が配設されており、磁石513が配管P1に密着することにより、第1支持フレーム51は配管P1に押し付けられた状態で密着する。これにより、第1支持フレーム51に収容された第1送受信探触子2および第2送受信探触子3も、配管P1に押し付けられた状態で密着する。
A magnet 513 (see FIGS. 3 and 5) is disposed below the lower connection arm 512 (on the pipe P1 side). When the
第2支持フレーム52は、図3、図4に示すように、受信探触子4を、第1送受信探触子2および第2送受信探触子3から送信されたSHガイド波W1の伝播方向に、配管P1に押し付けた状態で支持するものである。第2支持フレーム52は、受信探触子4を収容可能な箱形に形成されている。第2支持フレーム52に収容された受信探触子4は、底面部が配管P1に押圧されて密着する。また、図4に示すように、第2支持フレーム52に収容された受信探触子4は、アーム52Aによって、第1送受信探触子2および第2送受信探触子3の中心線上に位置して支持される。アーム52Aは、図3に示すように、第2支持フレーム52を、第1支持フレーム51に対して摺動自在に配設している。
As shown in FIGS. 3 and 4, the
より詳しくは、アーム52Aは、ピン52aによって第1支持フレーム51に対して摺動自在である。このため、アーム52Aを摺動して第2支持フレーム52を持ち上げると、第2支持フレーム52に収容された受信探触子4が配管P1から離接する。また、ピン52bによってアーム52Aに対して第2支持フレーム52が摺動自在である。このため、第2支持フレーム52に収容された受信探触子4は配管P1に対する傾きが調節自在である。
More specifically, the
このように、第2支持フレーム52はアーム52Aを介して第1支持フレーム51に配設されており、配管P1からの反射波W2を受信した第1支持フレーム51に支持された第1送受信探触子2および第2送受信探触子3と、参照波W3を受信した第2支持フレーム52に支持された受信探触子4との間隔は所定距離となる。
Thus, the
第2支持フレーム52の下側には、磁石521(図3参照)が配設されており、第2支持フレーム52は配管P1に押し付けられた状態で密着する。これにより、第2支持フレーム52に収容された受信探触子4も、配管P1に押し付けられた状態で密着する。
A magnet 521 (see FIG. 3) is disposed below the
ハンドル53は、第1支持フレーム51に配設されており、探触子設置治具5の運搬時や検査時の取り回しを容易にするものである。
The
このような構成の探触子設置治具5を配管P1に取り付ける際には、側板511がSHガイド波W1の伝播方向と正対した状態で取り付けられると、第1支持フレーム51に収容された第1送受信探触子2および第2送受信探触子3は、SHガイド波W1の伝播方向に並列に配設される。
When the
送受信装置6は、予め設定されたパラメータに基づいてチャープ波やバースト波を発生させるために、第1送受信探触子2および第2送受信探触子3の各振動子に、高周波のパルス電圧を加えることにより振動を生じさせてSHガイド波W1を発生させる制御をする。また、送受信装置6は、第1送受信探触子2および第2送受信探触子3、受信探触子4の各振動子の振動により生じた振動を電気信号に変えて受信する制御をする。送受信装置6と、第1送受信探触子2および第2送受信探触子3とは、信号線でそれぞれ接続される。
The transmission /
PC8は、反射波W2や参照波W3を保存したり、評価したりするための端末装置である。PC8は、図1に示すように、送受信装置6と、通信線でそれぞれ接続されており、相互に通信可能である。PC8は、図2に示すように、主として、記憶部81と、相関処理部82と、評価処理部83と、画像生成処理部84と、表示部85と、これらを制御などする制御部80とを備えている。
The
記憶部81は、送受信装置6から伝送された反射波W2の波形情報や、参照波W3の波形情報を記憶したり、相関処理部82や、評価処理部83、画像生成処理部84のプログラムやタスクを記憶したり、情報処理に必要なデータを記憶したりする。また、記憶部81は、反射波W2や参照波W3、相関波W4(図6参照)の波形情報とともに、計測時における第1送受信探触子2や、第2送受信探触子3、受信探触子4の配管P1の周方向位置を含む計測条件情報を記憶する。さらに、記憶部81は、配管Pの管径、板厚、長さ、埋設条件を含む配管情報を記憶する。
The storage unit 81 stores the waveform information of the reflected wave W2 transmitted from the transmission /
相関処理部82は、信号識別性を向上させる機能を有する。より詳しくは、相関処理部82は、図6、図12に示すように、受信探触子4が受信した参照波W3の波形情報と、第1送受信探触子2および第2送受信探触子3が受信した反射波W2の波形情報とに基づいて相関処理を行い、相関波W4の波形情報を算出する機能を有するプログラム、タスクである。この相関処理部82は、例えば、後述する図7に示すフローチャートにおけるステップS1の計測処理が終了したタイミングや、ユーザが指定した任意のタイミングで起動するように制御部80が制御する。ここで、計測処理が終了したか否かは、第1送受信探触子2および第2送受信探触子3による反射波W2の計測と、受信探触子4による参照波W3の計測が配管P1の全周に亘って終了したか否かによって判定する。
The
この相関処理部82における相関処理は、反射波W2の中で参照波W3と周波数成分などが類似した信号を高い値として出力する。具体的には、参照波W3の波形情報をh(t)とし、反射波W2の波形情報をx(t+τ)とすると、相関波W4の波形情報z(τ)は次式で算出される。
z(τ)=∫h(t)x(t+τ)dt
このように相関処理部82によって算出された相関波W4の波形情報は、記憶部81に記憶する。また、相関処理部82によって算出された相関波W4の波形情報は、反射波W2に混在するノイズを除去されたものである。
The correlation processing in the
z (τ) = ∫h (t) x (t + τ) dt
The waveform information of the correlation wave W4 calculated by the
評価処理部83は、相関処理部82によって算出された相関波W4の波形情報に基づいて、配管P2における(1)腐食Xの位置(軸方向の距離、周方向位置)を算出、(2)腐食Xの深さを推定して、腐食Xを評価する処理を行う機能を有するプログラム、タスクである。この評価処理部83は、例えば、図6に示すように相関処理部82における処理の終了に続いて起動するように制御部80が制御する。
The
(1)腐食Xの位置の算出
腐食Xの配管P2の軸方向の距離は、SHガイド波W1の送信時刻と反射波W2の受信時刻との差異に基づいて算出することができる。また、腐食Xの配管P2の周方向位置は、反射波W2を受信した第1送受信探触子2および第2送受信探触子3の配管P1の周方向位置に基づいて算出する。具体的には、第1送受信探触子2および第2送受信探触子3の中心線上に腐食Xが位置する際に、SHガイド波W1の伝播経路が最短となり、算出する軸方向の距離も最短となる。第1送受信探触子2および第2送受信探触子3の中心線から腐食Xが遠くなるほど、SHガイド波W1の伝播経路が長くなり、算出する軸方向の距離も長くなる。このため、反射波W2を受信した第1送受信探触子2および第2送受信探触子3の配管P1の周方向位置が異なる複数のデータを比較することにより、腐食Xの配管P2の周方向位置を算出することができる。すなわち、反射波W2を受信した第1送受信探触子2および第2送受信探触子3の配管P1の周方向位置に応じた反射波W2の推移を比較することにより、腐食Xの配管P2の周方向位置を得ることができる。このようにして、腐食Xの位置(軸方向の距離、周方向位置)を算出する。
(1) Calculation of the position of the corrosion X The distance in the axial direction of the pipe P2 of the corrosion X can be calculated based on the difference between the transmission time of the SH guide wave W1 and the reception time of the reflected wave W2. Further, the circumferential position of the corrosion X pipe P2 is calculated based on the circumferential position of the pipe P1 of the first transmission /
(2)腐食Xの深さの推定
腐食Xの深さは、反射波W2の信号強度に基づいて推定することができる。具体的には、腐食Xの深さを推定するしきい値となる評価基準データを管径、板厚ごとに予め記憶しておき、この評価基準データと、受信した反射波W2の信号強度とを比較することにより、腐食Xの深さを推定する。評価基準データは、管径、板厚が異なる試験用配管を用意し、実際の腐食Xの形状に近い形状で、深さの異なる人工腐食を形成する。そして、試験用配管上で計測位置を変化させて人工腐食による反射波W2の波形情報を距離に応じた信号値の推移情報として記憶する。このように、予め記憶した評価基準データの中から、配管P2に対応し、受信した反射波W2や計測位置などが対応するデータを取得して、腐食Xの深さを推定する。
(2) Estimation of depth of corrosion X The depth of corrosion X can be estimated based on the signal intensity of the reflected wave W2. Specifically, evaluation reference data serving as a threshold value for estimating the depth of corrosion X is stored in advance for each tube diameter and plate thickness, and the evaluation reference data and the signal intensity of the received reflected wave W2 are determined. To estimate the depth of the corrosion X. As the evaluation standard data, test pipes having different pipe diameters and plate thicknesses are prepared, and artificial corrosion with different depths is formed in a shape close to the actual shape of the corrosion X. Then, the measurement position is changed on the test pipe, and the waveform information of the reflected wave W2 caused by the artificial corrosion is stored as transition information of the signal value corresponding to the distance. Thus, the depth of the corrosion X is estimated by acquiring data corresponding to the pipe P2 and corresponding to the received reflected wave W2, the measurement position, and the like from the evaluation reference data stored in advance.
画像生成処理部84は、評価処理部83で算出した腐食Xの位置や深さを画像として生成する処理を行う機能を有するプログラム、タスクである。この画像生成処理部84は、例えば、図6に示すように評価処理部83における処理の終了に続いて起動するように制御部80が制御する。この実施形態では、図10、図11に示す画像を表示部85に出力するためのデータを生成する。図10は、縦軸を周方向位置、横軸を軸方向位置として、それぞれの位置における相関波W4の波形情報の信号強度をコントラストで表示したものである。ここでは、図中において矢印で示した位置に腐食Xが確認できる。図10からは、周方向位置がゼロに近いほど、軸方向の距離を小さく算出し、周方向位置の絶対値が大きくなるにつれて軸方向の距離を大きく算出する傾向を確認することができる。
The image
図11は、縦軸を信号値、横軸を軸方向位置として、軸方向位置における相関波W4の波形情報の信号強度を表示したものであり、評価基準データのしきい値が曲線で示されている。これにより、図11に示された信号値が2段階のしきい値に対してどの高さに相当するかによって腐食Xの深さを推定することができる。ここでは、図中において矢印で示した位置に腐食Xが確認できる。この腐食Xは、高い方のしきい値を超えており、所定値以上の深さであると推定できる。 FIG. 11 shows the signal intensity of the waveform information of the correlation wave W4 at the axial position, where the vertical axis is the signal value and the horizontal axis is the axial position, and the threshold value of the evaluation reference data is indicated by a curve. ing. Accordingly, the depth of the corrosion X can be estimated depending on which height the signal value shown in FIG. 11 corresponds to the two-stage threshold value. Here, corrosion X can be confirmed at a position indicated by an arrow in the figure. This corrosion X exceeds the higher threshold value, and can be estimated to be a depth of a predetermined value or more.
表示部85は、画像生成処理部84で生成した画像を表示する液晶ディスプレイなどの表示装置である。
The
制御部80は、相関処理部82や、評価処理部83、画像生成処理部84を図6に示す順序で起動するように制御する。
The
この実施形態に係る超音波検査装置1および探触子設置治具5は、以上のごとき構成からなり、以下、これらを使用した超音波検査方法とその作用について説明する。この実施形態では、図1に示すように、配管Pが、橋梁Bの橋桁B1下方に架設され(配管P1)、橋台B2を貫通(配管P2)している場合に、検査対象としての配管Pの腐食Xを検査する場合について説明する。この実施形態では、図7に示すように、まず、超音波検査装置1および探触子設置治具5を用いて、SHガイド波W1を送信して、反射波W2および参照波W3を計測して(ステップS1)、その後、記憶した反射波W2および参照波W3に基づいて評価を行う(ステップS2)。
The
まず、作業者によって、配管P1の配管P2側の外周面に、超音波検査装置1の設置位置が罫書きされる。この罫書き線は、超音波検査装置1を各罫書き線上に配設して計測することを繰り返すと配管P1の全周に亘って計測できるように、配管P1の外周面を周方向に等分割するものである。
First, the installation position of the
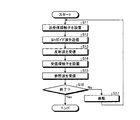
つぎに、図7に示すステップS1、すなわち、図8の超音波検査方法の計測処理手順を示すフロー図に沿って、SHガイド波W1を送信して、反射波W2および参照波W3を計測する処理について説明する。まず、作業者によって、配管P1の罫書き線上に、超音波検査装置1が設置される(ステップS11)。このとき、第1支持フレーム51の側板511が配管P1の周方向に沿った状態、すなわち、側板511がSHガイド波W1の伝播方向と正対した状態で配設される。また、第1支持フレーム51によって支持された第1送受信探触子2および第2送受信探触子3は、磁石513や磁石521によって配管P1に押し付けられて密着している。さらに、第2支持フレーム52は第1支持フレーム51に対して摺動されて持ち上げられた状態となっており、第2支持フレーム52に収容された受信探触子4は配管P1から離接されている。
Next, the SH guide wave W1 is transmitted and the reflected wave W2 and the reference wave W3 are measured according to step S1 shown in FIG. 7, that is, a flowchart showing the measurement processing procedure of the ultrasonic inspection method shown in FIG. Processing will be described. First, the
そして、超音波検査装置1の第1送受信探触子2および第2送受信探触子3によってSHガイド波W1が送信されて(ステップS12)、第1送受信探触子2および第2送受信探触子3によって反射波W2が受信される(ステップS13)。第1送受信探触子2および第2送受信探触子3によって受信された反射波W2の波形情報は、送受信装置6によってデジタル化されて、第1送受信探触子2および第2送受信探触子3の配管P1の周方向位置を含む計測情報として、PC8の制御部80によって記憶部81に記憶される。
Then, the SH guide wave W1 is transmitted by the first transmission /
そして、作業者によって、第2支持フレーム52が摺動されて受信探触子4が配管P1に密着するまで降下される(ステップS14)。そして、超音波検査装置1の受信探触子4によって参照波W3が受信される(ステップS15)。受信探触子4によって受信された参照波W3の波形情報は、送受信装置6によってデジタル化されて、受信探触子4の配管P1の周方向位置とともに、PC8の制御部80によって記憶部81に記憶される。
Then, the operator lowers the
そして、作業者によって、配管P1の罫書き線上のすべての位置での計測が終了したか否かが確認されて(ステップS16)、終了していない場合(「No」の場合)は、作業者によって、探触子設置治具5のハンドル53が把持されて、探触子設置治具5が配管P1から取り外されて、隣の罫書き線上に移動される(ステップS17)。そして、ステップS11からS16の処理が繰り返されて、反射波W2の計測情報と参照波W3の波形情報とがPC8の制御部80によって記憶部81に記憶される。このような処理が、配管P1の罫書き線上のすべての位置での計測が終了するまで(ステップS16において「Yes」と判定されるまで)繰り返される。
Then, it is confirmed by the operator whether or not the measurement at all positions on the ruled line of the pipe P1 has been completed (step S16). If the measurement has not been completed (in the case of “No”), the operator As a result, the
このようにして、探触子設置治具5が配管P1の周方向に移動して反射波W2および参照波W3を計測する処理が繰り返されると、配管P2の全周に亘って超音波検査装置1によって反射波W2と参照波W3が計測されて、反射波W2の計測情報と参照波W3の波形情報とがPC8の制御部80によって記憶部81に記憶される。
In this manner, when the
つづいて、図7に示すステップS2、すなわち、図9の超音波検査方法の評価処理手順を示すフロー図に沿って、記憶した反射波W2の計測情報および参照波W3の波形情報に基づいて評価を行う処理について説明する。まず、超音波検査装置1の相関処理部82によって、PC8の記憶部81に記憶された反射波W2の計測情報と参照波W3の波形情報とに基づいて、反射波W2の中で参照波W3と類似した信号が高い値として出力されて、相関波W4の波形情報が出力される(ステップS21)。そして、評価処理部83によって、相関処理部82で出力された相関波W4の波形情報に基づいて、その信号強度から、腐食Xの位置と腐食Xの深さが算出される(ステップS22)。そして、画像生成処理部84によって、評価処理部83で算出した腐食Xの位置や深さに基づいて、画像が生成されて(ステップS23)、表示部85に図10や図11に示す画像として出力される(ステップS24)。
Subsequently, evaluation is performed based on the stored measurement information of the reflected wave W2 and the waveform information of the reference wave W3 in accordance with step S2 shown in FIG. 7, that is, the flowchart showing the evaluation processing procedure of the ultrasonic inspection method of FIG. The process of performing will be described. First, based on the measurement information of the reflected wave W2 and the waveform information of the reference wave W3 stored in the storage unit 81 of the
そして、作業者によって、PC8の表示部85に表示された図10や図11の画像が確認されて、配管P2の全周に亘って腐食Xの有無やその位置、深さが確認される。
Then, the operator confirms the images of FIG. 10 and FIG. 11 displayed on the
以上の超音波検査方法によって、超音波検査装置1および探触子設置治具5を用いて、配管P2に向けてSHガイド波W1を送信して、受信探触子4が受信した参照波W3と、第1送受信探触子2および第2送受信探触子3が受信した反射波W2とに基づいて相関処理部82によって相関処理を行う。これにより、実際に配管P2を伝播して受信探触子4が受信した参照波W3に基づいて相関処理するため、相関処理における整合性の精度が改善されて信号識別性が向上し、検査精度をより向上することができる。
With the above ultrasonic inspection method, the reference wave W3 received by the receiving probe 4 is transmitted by transmitting the SH guide wave W1 toward the pipe P2 using the
また、超音波検査装置1は、第1送受信探触子2および第2送受信探触子3は、SHガイド波W1の伝播方向に並列に配設されている。このため、上述した見かけの送受信探触子においては、2つのSHガイド波W1が合成されるので、第1送受信探触子2と第2送受信探触子3のそれぞれから出力されるSHガイド波W1や反射波W2に比べて出力レベルを増大することができる。また、見かけの送受信探触子は、第1送受信探触子2と第2送受信探触子3のそれぞれに比べて指向性を向上することができる。これにより、超音波検査装置1は、SHガイド波W1や反射波W2に比べて出力レベルが増大し、指向性が向上するので、検査精度をより向上することができる。
In the
ここで、以上の超音波検査装置1および探触子設置治具5を用いた超音波検査方法(以下、「この実施形態に係る超音波検査方法」)と従来の超音波検査装置10を用いた超音波検査方法(以下、「従来の超音波検査方法」という。)との効果を対比するために、図13に示す、同一の試験体Qを用いて同一の条件で、超音波検査装置1および探触子設置治具5を用いた超音波検査を行った。具体的に、試験体Qは、SGP(配管用炭素鋼管)の200Aを使用する。試験体Qには、外周面に模擬腐食X1を形成する。模擬腐食X1は、直径5mm、試験体Qの板厚(5.8mm)の3分の1の深さ(1.9mm)のすり鉢状の溝を、試験体Qの軸方向に2つ、周方向に2つを隣接して4つ形成したものである。超音波検査装置1の第1送受信探触子2および第2送受信探触子3または従来の超音波検査装置10の送受信探触子は、模擬腐食X1から軸方向に1000mm離間して配設する。なお、従来の超音波検査装置10は、第1送受信探触子2や第2送受信探触子3と同等の構成を有する1つの送受信探触子を用いて反射波を測定するものである。従来の超音波検査装置10は、超音波検査装置1の受信探触子4、探触子設置治具5、PC8を備えていない。
Here, the ultrasonic inspection method using the
図14は、従来の超音波検査方法における信号識別性を説明する図であり、図15は、この実施形態に係る超音波検査方法における信号識別性を説明する図である。図15は、模擬腐食X1を示す信号値のノイズレベルに対する比率が約10となり、ノイズレベルとの差異が明確である。これに対して、図14は、模擬腐食X1を示す信号値のノイズレベルに対する比率が約2となり、ノイズレベルとの差異が小さい。これらにより、従来の超音波検査方法に比べて、この実施形態に係る超音波検査方法は、模擬腐食X1の信号識別性が向上したことが確認できる。これは、この実施形態に係る超音波検査方法においては、第1送受信探触子2および第2送受信探触子3が並列に配設されているので、上述した見かけの送受信探触子における反射波W2の出力レベルが増大して信号値が大きくなったためである。また、この実施形態に係る超音波検査方法においては、相関処理部82における相関処理によって、反射波W2のノイズレベルが低減された相関波W4が得られたためである。
FIG. 14 is a diagram for explaining signal discrimination in the conventional ultrasonic inspection method, and FIG. 15 is a diagram for explaining signal discrimination in the ultrasonic inspection method according to this embodiment. In FIG. 15, the ratio of the signal value indicating the simulated corrosion X1 to the noise level is about 10, and the difference from the noise level is clear. On the other hand, in FIG. 14, the ratio of the signal value indicating the simulated corrosion X1 to the noise level is about 2, and the difference from the noise level is small. Accordingly, it can be confirmed that the signal discrimination of the simulated corrosion X1 is improved in the ultrasonic inspection method according to this embodiment as compared with the conventional ultrasonic inspection method. This is because, in the ultrasonic inspection method according to this embodiment, the first transmission /
図16は、この実施形態に係る超音波検査方法における指向性と従来の超音波検査方法における指向性とを説明する図である。これは、試験体Qを用いて、超音波検査装置1の第1送受信探触子2および第2送受信探触子3または従来の超音波検査装置10の送受信探触子を模擬腐食X1と正対した位置(周位置(周方向の位置)0mm)から試験体Qの周方向に約50mmずつずらして計測を行った際の模擬腐食X1を示す信号値の推移を示したものである。この実施形態に係る超音波検査方法によれば、第1送受信探触子2および第2送受信探触子3を模擬腐食X1と正対した位置から離すほど(周位置の絶対値が大きくなるほど)模擬腐食X1を示す信号値が低下している。より詳しくは、模擬腐食X1を示す信号値は、周位置0mmのとき約72mVで最大値となり、周位置−150mmのとき約19mV(なお、周位置150mmのときは約21mV)で最小値となる。これに対して、従来の超音波検査方法によれば、模擬腐食X1を示す信号値は、周位置0mmのとき約24mVで最大値となり、周位置150mmのとき約11mV(なお、周位置−150mmのときは約14mV)で最小値となり、最大値と最小値の差異が小さい。これにより、従来の超音波検査方法に比べて、この実施形態に係る超音波検査方法は、周位置による信号値の差が明確になり、指向性が向上したことが確認できる。これは、この実施形態に係る超音波検査方法においては、上述した見かけの送受信探触子が第1送受信探触子2と第2送受信探触子3のそれぞれに比べて指向性が向上するためである。
FIG. 16 is a diagram for explaining the directivity in the ultrasonic inspection method according to this embodiment and the directivity in the conventional ultrasonic inspection method. This is because the test body Q is used to correct the first transmission /
また、探触子設置治具5によって、第1送受信探触子2および第2送受信探触子3と、受信探触子4とは配管P1に着脱自在に設置され、配管P2からの反射波W2を受信した第1送受信探触子2および第2送受信探触子3と、SHガイド波W1を参照波W3として受信した第2支持フレーム52に支持された受信探触子4との間隔は所定距離とされる。このため、超音波検査方法において、第1送受信探触子2および第2送受信探触子3と、受信探触子4とを配管P1に容易に着脱できる。このため、検査に要する手間と時間とを削減することができる。
Further, the first transmission /
[第2実施形態]
第2実施形態に係る超音波検査方法は、超音波検査装置1および探触子設置治具5を用いて、予め試験用配管によって参照波W3を測定しておく点で第1実施形態とは異なる。その他、上述した実施形態と共通する構成、作用、効果については、重複した説明はできるだけ省略し、また、概略構成については、適宜図1等を参照する。上述した実施形態と共通、対応する構成には、同一または対応する符号を付すものとする。
[Second Embodiment]
The ultrasonic inspection method according to the second embodiment is different from the first embodiment in that the reference wave W3 is measured in advance by a test pipe using the
まず、検査対象の配管Pと同一材料で、同等の管径、板厚、長さで、配管Pと同様の環境に設置した試験用配管を用意する。作業者は、試験用配管に、配管Pと同様に罫書きする。そして、試験用配管に、第1送受信探触子2および第2送受信探触子3と、受信探触子4とを探触子設置治具5を介して設置する。そして、作業者は、探触子設置治具5を試験用配管の周方向に移動して、超音波検査装置1によって、参照波W3のみを計測する処理を繰り返して、試験用配管の全周に亘って参照波W3を計測して、参照波W3の波形情報をPC8の制御部80によって記憶部81に記憶する。また、温度、湿度を変えて異なる計測条件における参照波W3を計測して事前計測データとして記憶する。
First, a test pipe that is made of the same material as the pipe P to be inspected and has the same pipe diameter, plate thickness, and length and is installed in the same environment as the pipe P is prepared. The operator marks the test pipe in the same manner as the pipe P. Then, the first transmission /
そして、計測を行う現地では、作業者は、探触子設置治具5を配管P1の周方向に移動して、超音波検査装置1によって、反射波W2のみを計測する処理を繰り返して、配管P2の全周に亘って反射波W2を計測して、反射波W2の計測情報をPC8の制御部80によって記憶部81に記憶する。
Then, at the site where the measurement is performed, the operator moves the
そして、記憶部81から、現地作業時の温度、湿度などの計測条件に対応する参照波W3の事前計測データを取得して、記憶した反射波W2および取得した参照波W3の事前計測データに基づいて評価を行う(図7に示すステップS2)。 And the pre-measurement data of the reference wave W3 corresponding to measurement conditions, such as temperature at the time of field work, humidity, etc. are acquired from the memory | storage part 81, and based on the stored pre-measurement data of the reflected wave W2 and the acquired reference wave W3 To evaluate (step S2 shown in FIG. 7).
以上で説明した超音波検査方法は、試験用配管を用いて、予め参照波W3を計測して事前計測データとして記憶しておくため、現地作業時は反射波W2のみを計測すればよい。このため、配管Pにおける現地作業を削減することができる。 In the ultrasonic inspection method described above, since the reference wave W3 is measured in advance using test pipes and stored in advance as measurement data, only the reflected wave W2 needs to be measured during field work. For this reason, the field work in the piping P can be reduced.
なお、上述した本発明の実施形態に係る超音波検査方法および探触子設置治具5は、上述した実施形態に限定されず、特許請求の範囲に記載された範囲で種々の変更が可能である。この実施形態に係る超音波検査方法および探触子設置治具5は、以上で説明した各実施形態、変形例の構成要素を適宜組み合わせることで構成してもよい。
The ultrasonic inspection method and the
例えば、PC8は、既知のパーソナルコンピュータ、ワークステーション等の情報処理装置として構成すればよく、また、該情報処理装置に任意の周辺装置を接続して構成してもよい。また、PC8は、該情報処理装置に本発明の方法を実現させるソフトウェア(プログラム、データ等を含む)を実装することにより実現してもよい。
For example, the
また、PC8と送受信装置6とは、通信線で接続されているものとしたが、無線通信で相互に通信可能であってもよい。
The
さらに、探触子設置治具5を配管Pの周方向に沿ってスライド自在にするレールなどのスライド機構を設けてもよい。
Furthermore, a slide mechanism such as a rail that makes the
1 超音波検査装置
2 第1送受信探触子(計測用送受信探触子)
3 第2送受信探触子(計測用送受信探触子)
4 受信探触子
5 探触子設置治具
51 第1支持フレーム
52 第2支持フレーム
53 ハンドル
6 送受信装置
8 PC
81 記憶部
82 相関処理部
83 評価処理部
84 画像生成処理部
85 表示部
W1 SHガイド波
W2 反射波
W3 参照波
W4 相関波
B 橋梁
B1 橋桁
B2 橋台
P 配管(検査対象)
P1 配管
P2 配管
X 腐食
DESCRIPTION OF
3 Second transmitter / receiver probe (transmission / reception probe for measurement)
4
81
P1 piping P2 piping X Corrosion
Claims (6)
受信探触子によって、前記計測用送受信探触子から送信された前記SHガイド波を参照波形として受信する参照波受信ステップと、
前記計測用送受信探触子によって、前記検査対象からの反射波を受信する反射波受信ステップと、
前記受信探触子が受信した前記参照波形と、前記計測用送受信探触子が受信した前記反射波とに基づいて相関処理を行う相関処理ステップと、
前記相関処理ステップによって得られた相関波形を出力する出力ステップと、
を備えることを特徴とする超音波検査方法。 An SH guide wave transmitting step of transmitting an SH guide wave toward the inspection object by the measurement transmission / reception probe;
A reference wave receiving step of receiving, as a reference waveform, the SH guide wave transmitted from the transmission / reception probe for measurement by a reception probe;
A reflected wave receiving step of receiving a reflected wave from the inspection object by the measurement transmission / reception probe;
A correlation processing step for performing correlation processing based on the reference waveform received by the reception probe and the reflected wave received by the transmission / reception probe for measurement;
An output step of outputting a correlation waveform obtained by the correlation processing step;
An ultrasonic inspection method comprising:
ことを特徴とする請求項1に記載の超音波検査方法。 A plurality of the transmission / reception probes for measurement are arranged in parallel in the propagation direction of the SH guide wave.
The ultrasonic inspection method according to claim 1.
を備え、
前記検査対象は、配管であり、
前記SHガイド波の伝播方向は、前記配管の軸方向と一致し、
前記検査対象の外周面の所定の場所において、前記SHガイド波送信ステップと前記参照波受信ステップと前記反射波受信ステップとを実施した後で、前記移動ステップを実施して前記検査対象の外周面を周方向に移動することを繰り返して、前記検査対象を全周に亘って検査する、
ことを特徴とする請求項1または2に記載の超音波検査方法。 A moving step of moving the transmission / reception probe for measurement and the reception probe in a direction different from a propagation direction of the SH guide wave to be inspected;
With
The inspection object is piping,
The propagation direction of the SH guide wave coincides with the axial direction of the pipe,
After performing the SH guide wave transmitting step, the reference wave receiving step, and the reflected wave receiving step at a predetermined location on the outer peripheral surface of the inspection target, the moving step is performed to perform the outer peripheral surface of the inspection target. Is repeatedly moved in the circumferential direction, and the inspection object is inspected over the entire circumference.
The ultrasonic inspection method according to claim 1 or 2.
前記計測用送受信探触子を、前記検査対象に押し付けた状態で支持する第1支持フレームと、
前記受信探触子を、前記計測用送受信探触子から送信された前記SHガイド波の伝播方向に、前記検査対象に押し付けた状態で支持する第2支持フレームと、
を備え、
前記第2支持フレームは前記第1支持フレームに配設されており、前記検査対象からの反射波を受信した前記第1支持フレームに支持された前記計測用送受信探触子と、前記SHガイド波を参照波形として受信した前記第2支持フレームに支持された前記受信探触子との間隔は所定距離となる、
ことを特徴とする探触子設置治具。 A probe installation jig used in the ultrasonic inspection method according to any one of claims 1 to 3, wherein the transmission / reception probe for measurement and the reception probe are detachably installed on the inspection target. Because
A first support frame for supporting the measurement transmission / reception probe in a state of being pressed against the inspection target;
A second support frame for supporting the reception probe in a state in which the reception probe is pressed against the inspection target in the propagation direction of the SH guide wave transmitted from the measurement transmission / reception probe;
With
The second support frame is disposed on the first support frame, and the transmission / reception probe for measurement supported by the first support frame that has received the reflected wave from the inspection object, and the SH guide wave. The distance from the reception probe supported by the second support frame received as a reference waveform is a predetermined distance.
A probe installation jig characterized by that.
前記第2支持フレームは、前記受信探触子を、複数の前記計測用送受信探触子の中心線上に位置して支持する、
ことを特徴とする請求項4に記載の探触子設置治具。 The first support frame supports a plurality of the transmission / reception probes for measurement in parallel in the propagation direction of the SH guide wave,
The second support frame supports the reception probe while being positioned on a center line of the plurality of transmission / reception probes for measurement,
The probe installation jig according to claim 4, wherein:
ことを特徴とする請求項4または5に記載の探触子設置治具。 The second support frame is slidably disposed with respect to the first support frame;
The probe installation jig according to claim 4 or 5, characterized in that
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2015107518A JP2016027321A (en) | 2014-07-03 | 2015-05-27 | Ultrasonic inspection method and probe installation jig |
Applications Claiming Priority (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2014137887 | 2014-07-03 | ||
| JP2014137887 | 2014-07-03 | ||
| JP2015107518A JP2016027321A (en) | 2014-07-03 | 2015-05-27 | Ultrasonic inspection method and probe installation jig |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| JP2016027321A true JP2016027321A (en) | 2016-02-18 |
Family
ID=55352754
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2015107518A Pending JP2016027321A (en) | 2014-07-03 | 2015-05-27 | Ultrasonic inspection method and probe installation jig |
Country Status (1)
| Country | Link |
|---|---|
| JP (1) | JP2016027321A (en) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2018221531A1 (en) | 2017-05-29 | 2018-12-06 | 学校法人近畿大学 | Method and device for reducing hto concentration in hto-containing aqueous solution |
| JP2021032610A (en) * | 2019-08-20 | 2021-03-01 | 首都高速道路株式会社 | Corrosion inspection method and corrosion inspection device for distant non-exposed part of inspection object |
| CN115980759A (en) * | 2023-03-17 | 2023-04-18 | 武汉理工大学三亚科教创新园 | Ultrasonic ranging device and ranging method for marine engineering construction |
Citations (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5498291A (en) * | 1978-01-20 | 1979-08-03 | Toshiba Corp | Simple type sonic flaw detector |
| JPH0279457U (en) * | 1988-12-07 | 1990-06-19 | ||
| JPH0464057A (en) * | 1990-07-04 | 1992-02-28 | Toshiba Corp | Ultrasonic probe |
| JP2002243704A (en) * | 2001-02-22 | 2002-08-28 | Osaka Gas Co Ltd | Method and device for inspecting corrosion |
| JP2003294714A (en) * | 2002-03-28 | 2003-10-15 | Katsuhiro Kawashima | Electromagnetic acoustic wave inspection device using cross-correlation method |
| JP2004020333A (en) * | 2002-06-14 | 2004-01-22 | Osaka Gas Co Ltd | Ultrasonic flaw detecting apparatus |
| JP2005037407A (en) * | 2004-11-05 | 2005-02-10 | Jfe Steel Kk | Ultrasonic flaw detection method and ultrasonic flaw detection apparatus |
| JP2008292385A (en) * | 2007-05-28 | 2008-12-04 | Jfe Engineering Kk | Sensitivity correction method for ultrasonic inspection |
| JP2009236620A (en) * | 2008-03-26 | 2009-10-15 | Jfe Engineering Corp | Ultrasonic flaw detection method |
| JP2010151667A (en) * | 2008-12-25 | 2010-07-08 | Jfe Steel Corp | Diagnosis device of tube body, and method therefor |
-
2015
- 2015-05-27 JP JP2015107518A patent/JP2016027321A/en active Pending
Patent Citations (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5498291A (en) * | 1978-01-20 | 1979-08-03 | Toshiba Corp | Simple type sonic flaw detector |
| JPH0279457U (en) * | 1988-12-07 | 1990-06-19 | ||
| JPH0464057A (en) * | 1990-07-04 | 1992-02-28 | Toshiba Corp | Ultrasonic probe |
| JP2002243704A (en) * | 2001-02-22 | 2002-08-28 | Osaka Gas Co Ltd | Method and device for inspecting corrosion |
| JP2003294714A (en) * | 2002-03-28 | 2003-10-15 | Katsuhiro Kawashima | Electromagnetic acoustic wave inspection device using cross-correlation method |
| JP2004020333A (en) * | 2002-06-14 | 2004-01-22 | Osaka Gas Co Ltd | Ultrasonic flaw detecting apparatus |
| JP2005037407A (en) * | 2004-11-05 | 2005-02-10 | Jfe Steel Kk | Ultrasonic flaw detection method and ultrasonic flaw detection apparatus |
| JP2008292385A (en) * | 2007-05-28 | 2008-12-04 | Jfe Engineering Kk | Sensitivity correction method for ultrasonic inspection |
| JP2009236620A (en) * | 2008-03-26 | 2009-10-15 | Jfe Engineering Corp | Ultrasonic flaw detection method |
| JP2010151667A (en) * | 2008-12-25 | 2010-07-08 | Jfe Steel Corp | Diagnosis device of tube body, and method therefor |
Cited By (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2018221531A1 (en) | 2017-05-29 | 2018-12-06 | 学校法人近畿大学 | Method and device for reducing hto concentration in hto-containing aqueous solution |
| JP2021032610A (en) * | 2019-08-20 | 2021-03-01 | 首都高速道路株式会社 | Corrosion inspection method and corrosion inspection device for distant non-exposed part of inspection object |
| JP7252093B2 (en) | 2019-08-20 | 2023-04-04 | 首都高速道路株式会社 | Corrosion inspection method and corrosion inspection device for remote non-exposed part of inspection object |
| CN115980759A (en) * | 2023-03-17 | 2023-04-18 | 武汉理工大学三亚科教创新园 | Ultrasonic ranging device and ranging method for marine engineering construction |
| CN115980759B (en) * | 2023-03-17 | 2023-05-16 | 武汉理工大学三亚科教创新园 | Ultrasonic ranging device and ranging method for ocean engineering construction |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP2857834B1 (en) | Ultrasonic pipe measurement apparatus | |
| CN100394174C (en) | Non-destructive inspection device and non-destructive inspection method using guided waves | |
| EP1709418B1 (en) | Method and apparatus for examining the interior material of an object, such as a pipeline or a human body from a surface of the object using ultrasound | |
| RU2017139770A (en) | INSTALLATION AND METHOD OF REMOTE MEASUREMENT OF GEOMETRIC PARAMETERS OF THE PIPELINE AT THE STAGE OF THE REMOVAL BY MEANS OF SOUND WAVES IN THE MODE OF REAL TIME | |
| JP4116483B2 (en) | Tubular ultrasonic inspection method and apparatus | |
| CN108283011A (en) | The variation in metal structure is detected and is monitored using multimode acoustical signal | |
| Ma et al. | The reflection of guided waves from simple dents in pipes | |
| JPS59131161A (en) | Method of monitoring structure | |
| JP4589280B2 (en) | Pipe inspection method using guide wave and pipe inspection apparatus | |
| JP5663319B2 (en) | Guide wave inspection method and apparatus | |
| US20130192334A1 (en) | Method and system for calibrating an ultrasonic wedge and a probe | |
| JP3725515B2 (en) | Nondestructive inspection equipment | |
| JP5530405B2 (en) | Nondestructive inspection method and nondestructive inspection device | |
| JP2009236620A (en) | Ultrasonic flaw detection method | |
| JP3198840U (en) | Prop road boundary inspection system | |
| JP4583898B2 (en) | Ultrasonic flaw detector | |
| CN112540399A (en) | Optical cable detection device and method | |
| JP2005221321A (en) | Ultrasonic signal detection method and apparatus | |
| JP6173636B1 (en) | Ultrasonic inspection method and ultrasonic inspection apparatus | |
| JP5195407B2 (en) | Tubular diagnosis apparatus and method | |
| JP2016205858A (en) | Defect inspection apparatus, control method therefor, program, and storage medium | |
| JP4526046B1 (en) | Inspection method using guide waves | |
| JP2013002822A (en) | Nondestructive check method and nondestructive check apparatus | |
| JP5750066B2 (en) | Non-destructive inspection method using guided waves | |
| JP2004309232A (en) | Apparatus for evaluating crack in concrete pole |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20170911 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20180814 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20180815 |
|
| A02 | Decision of refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A02 Effective date: 20190226 |