JP2009037377A - Verification simulator for programmable controller with pid process control function and verification system using the same - Google Patents
Verification simulator for programmable controller with pid process control function and verification system using the same Download PDFInfo
- Publication number
- JP2009037377A JP2009037377A JP2007200425A JP2007200425A JP2009037377A JP 2009037377 A JP2009037377 A JP 2009037377A JP 2007200425 A JP2007200425 A JP 2007200425A JP 2007200425 A JP2007200425 A JP 2007200425A JP 2009037377 A JP2009037377 A JP 2009037377A
- Authority
- JP
- Japan
- Prior art keywords
- control
- current value
- verification
- programmable controller
- pid
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
- 238000012795 verification Methods 0.000 title claims abstract description 49
- 238000004886 process control Methods 0.000 title claims abstract description 18
- 230000007423 decrease Effects 0.000 claims description 6
- 230000003111 delayed effect Effects 0.000 claims description 5
- 230000002708 enhancing effect Effects 0.000 abstract 1
- 230000006870 function Effects 0.000 description 8
- 230000004044 response Effects 0.000 description 8
- 238000006243 chemical reaction Methods 0.000 description 7
- 230000009471 action Effects 0.000 description 4
- 230000008859 change Effects 0.000 description 4
- 230000003247 decreasing effect Effects 0.000 description 3
- 238000010586 diagram Methods 0.000 description 3
- 230000001174 ascending effect Effects 0.000 description 2
- 230000008901 benefit Effects 0.000 description 1
- 239000003990 capacitor Substances 0.000 description 1
- 230000001934 delay Effects 0.000 description 1
- 230000009699 differential effect Effects 0.000 description 1
- 230000001771 impaired effect Effects 0.000 description 1
- 238000004519 manufacturing process Methods 0.000 description 1
- 238000000034 method Methods 0.000 description 1
- 238000002360 preparation method Methods 0.000 description 1
- 230000008569 process Effects 0.000 description 1
- 230000000630 rising effect Effects 0.000 description 1
- 238000003860 storage Methods 0.000 description 1
Images


Landscapes
- Programmable Controllers (AREA)
Abstract
Description
本発明は、目標値と制御対象からのフィードバック値である現在値との偏差に基づいてPID演算を行うと共に、このPID演算結果に対応した制御出力を制御対象に出力するPIDプロセス制御機能付きプログラマブルコントローラ(プログラマブルロジックコントローラとも称する)に対し、そのPIDプロセス制御機能の検証を行うため上記制御対象に代えて用いる検証シミュレータに関するものである。 The present invention performs a PID calculation based on a deviation between a target value and a current value that is a feedback value from a controlled object, and also a programmable with a PID process control function that outputs a control output corresponding to the PID calculation result to the controlled object. The present invention relates to a verification simulator used for a controller (also referred to as a programmable logic controller) in place of the control object in order to verify the PID process control function.
特許文献1にも開示されているように、プログラマブルコントローラは、制御対象をシーケンス制御するための基本命令と、四則演算や比較等の簡単な応用命令を実行することができる。 As disclosed in Patent Document 1, the programmable controller can execute basic instructions for sequence-controlling the controlled object and simple application instructions such as four arithmetic operations and comparisons.
一方、PIDプロセス制御命令を備えてPIDプロセス制御を行うのに用いることができるプログラマブルコントローラも開発されている。 On the other hand, a programmable controller that has a PID process control command and can be used to perform PID process control has also been developed.
図3を参照してPIDプロセス制御を実行する機能を備えたプログラマブルコントローラ1は、目標値入力部5からの目標値と現在値入力部7からの現在値(制御対象21からのフィードバック値)との偏差に基づいてPID演算部9でPID演算を行うと共にこのPID演算結果を制御出力部11から制御出力として出力し、DA変換部17でDA変換して制御対象21に出力する。
The programmable controller 1 having a function of executing PID process control with reference to FIG. 3 includes a target value from the target
制御対象21として例えば電気炉を挙げると、電気炉は内部にヒータ23を備え、このヒータ23と電源25との間にスイッチ制御部27を介挿すると共に、電気炉内に温度センサ29を配置している。
For example, when an electric furnace is given as the control target 21, the electric furnace includes a
そして、スイッチ制御部27をPID制御してヒータ23への供給電力を調節して電気炉内温度を目標値(目標温度)に制御して電気炉内の被加熱物31を加熱する場合、温度センサ29で電気炉内現在値(現在温度)を計測し、その計測した現在値をプログラマブルコントローラ1ではAD変換部19でAD変換して現在値入力部7に与える。
When the
このプログラマブルコントローラは、図示はしないが、例えばビルディングブロックタイプとして、電源ユニットと、CPUユニットと、DA変換ユニットと、AD変換ユニットとを備えて構成し、CPUユニットでは、CPU、プログラムメモリ、データメモリ等を備え、そのCPUにてPID演算を行うと共に、そのデジタル値であるPID演算結果をDA変換ユニットでDA変換し、制御対象からの現在値はAD変換ユニットでAD変換するようにしてもよい。 Although not shown in the figure, this programmable controller includes, for example, a building block type including a power supply unit, a CPU unit, a DA conversion unit, and an AD conversion unit. The CPU unit includes a CPU, a program memory, and a data memory. Etc., the PID calculation is performed by the CPU, the digital value PID calculation result is DA-converted by the DA conversion unit, and the current value from the controlled object is AD-converted by the AD conversion unit. .
上記PIDプロセス制御は比例動作(P)、積分動作(I)、微分動作(D)を組み合わせて制御対象のプロセスを制御するものであり、比例動作でハンチングのない滑らかな制御を行い、積分動作でオフセットを自動的に修正し、微分動作で外乱に対する応答を早くすることができる。 The above PID process control is a combination of proportional action (P), integral action (I), and differential action (D) to control the process to be controlled. The proportional action performs smooth control without hunting, and the integral action. The offset can be automatically corrected with, and the response to the disturbance can be accelerated by the differential operation.
以上の構成を備えた電気炉制御のためのプログラマブルコントローラを設計製造した後、ユーザにそのプログラマブルコントローラを納品する前に、
そのプログラマブルコントローラがその電気炉を制御対象として適切にPIDプロセス制御を行うか否かの検証を実施することが必要である。
After designing and manufacturing a programmable controller for electric furnace control with the above configuration, before delivering the programmable controller to the user,
It is necessary to verify whether or not the programmable controller appropriately performs PID process control with the electric furnace as a control target.
検証を実施する準備として、ユーザが使用する可能性がある電気炉を想定したアプリケーションを製作する必要がある。 In preparation for the verification, it is necessary to produce an application that assumes an electric furnace that the user may use.
そのため、上記検証には時間がかかる。また、アプリケーションを動作させて検証を行う環境作りにも相当な手間とコストとがかかることに加えて、アプリケーションを動作させるには場合によっては検証上の安全性が損なわれることがある。
本発明の目的は、プログラマブルコントローラのPID演算動作の検証に要する時間の短縮化と、手間の削減化と、コストの低減化と、検証上の安全性向上とを可能とすることである。 An object of the present invention is to shorten the time required for verifying the PID calculation operation of the programmable controller, to reduce labor, to reduce costs, and to improve safety in verification.
この目的を解決する為の課題としては、ユーザが使用するアプリケーションと同等の動作を持たせることが可能なアプリケーションソフトウェアを作成することができ、また、ユーザが使用するアプリケーションが構成するPIDの制御対象物は多品種存在しそれぞれ動きが異なっても、その多品種の動きをどのようにしてアプリケーションソフトに組み込むかが課題になる。 As a problem to solve this object, it is possible to create application software capable of having the same operation as the application used by the user, and to control the PID configured by the application used by the user. Even if there are many kinds of products and their movements are different, how to incorporate the movements of the various kinds into the application software becomes a challenge.
本発明に係る検証シミュレータは、目標値と制御対象からのフィードバック値である現在値との偏差に基づいてPID演算を行うと共にこのPID演算結果に対応した制御出力を制御対象に出力するPIDプロセス制御機能付きプログラマブルコントローラに対しそのPIDプロセス制御機能の検証を行うため上記制御対象に代えて用いる検証シミュレータであって、上記制御出力を入力すると共に、上記制御対象の熱容量に対応した時間分遅らせて出力するバッファ部と、上記バッファ部から出力される制御出力と上記制御対象の熱容量とに対応して現在値を演算して上記プログラマブルコントローラに与える演算部と、を備えたことを特徴とするものである。 The verification simulator according to the present invention performs PID calculation based on a deviation between a target value and a current value that is a feedback value from a control target, and outputs a control output corresponding to the PID calculation result to the control target. A verification simulator used in place of the control object for verifying the PID process control function for a programmable controller with a function, which inputs the control output and outputs it delayed by a time corresponding to the heat capacity of the control object And a calculation unit that calculates a current value corresponding to the control output output from the buffer unit and the heat capacity to be controlled and supplies the current value to the programmable controller. is there.
本発明によると、プログラマブルコントローラから目標値と現在値との偏差に対応したPID演算結果である制御出力が検証シミュレータに入力されると、検証シミュレータでは、入力された制御出力を、バッファ部で制御対象の熱容量に対応した応答遅れの後に演算部で演算させるので、演算部からプログラマブルコントローラに入力される現在値を実際の制御対象を用いて検証したと同様に変化させることができる。そのため、本発明では、ユーザが使用する可能性がある多品種の制御対象に対し、そのプログラマブルコントローラが持つPID演算機能が適切に機能するか否かの検証を検証シミュレータで行うことが可能となり、従来のように上記検証を実施するに際してユーザが使用する電気炉を想定したアプリケーションを製作する必要がなくなり、また、アプリケーションを動作させて検証を行う環境作りも特に必要としなくなり、さらに検証上の安全性も確保することができる。 According to the present invention, when a control output that is a PID calculation result corresponding to the deviation between the target value and the current value is input from the programmable controller to the verification simulator, the verification simulator controls the input control output by the buffer unit. Since the calculation unit calculates after a response delay corresponding to the heat capacity of the target, the current value input from the calculation unit to the programmable controller can be changed in the same manner as the verification using the actual control target. Therefore, in the present invention, it becomes possible to verify whether or not the PID calculation function of the programmable controller functions properly for a variety of control objects that the user may use, with a verification simulator, It is no longer necessary to create an application that assumes the electric furnace to be used by the user when performing the verification as in the past, and it is not necessary to create an environment for performing verification by operating the application. Sex can be secured.
好ましい態様の1つは、上記バッファ部は、複数段のシフトレジスタが縦続接続されてなり、かつ、初段のシフトレジスタに入力した制御出力を次段以降のシフトレジスタに順次に単位時間ごとにシフトさせていき、終段のシフトレジスタから上記演算部に出力するよう構成されていることである。 One of the preferred embodiments is that the buffer unit is formed by cascading multiple stages of shift registers, and the control output input to the first stage shift register is sequentially shifted to the next and subsequent shift registers every unit time. In other words, it is configured to output from the last-stage shift register to the arithmetic unit.
好ましい態様の1つは、上記現在値演算部は、現在値をPV、制御出力をVout、時間をt、熱容量をCRとすると、現在値PVを増加させる場合はPV=Vout×[1−ε(-t/CR)]、現在値PVを減少させる場合はPV=Vout×[ε(-t/CR)]の式で現在値を演算することである。 One of the preferred embodiments is that the current value calculation unit is PV = Vout × [1-ε when the current value PV is increased, assuming that the current value is PV, the control output is Vout, the time is t, and the heat capacity is CR. (−t / CR) ], to decrease the current value PV, the current value is calculated by the equation PV = Vout × [ε (−t / CR) ].
本発明に係る検証システムは、目標値と制御対象からのフィードバック値である現在値との偏差に基づいてPID演算を行うと共にこのPID演算結果に対応した制御出力を制御対象に出力する、PIDプロセス制御機能付きプログラマブルコントローラと、上記本発明の検証シミュレータとを備えた、ことを特徴とするものである。 A verification system according to the present invention performs a PID calculation based on a deviation between a target value and a current value that is a feedback value from a control target, and outputs a control output corresponding to the PID calculation result to the control target. A programmable controller with a control function and the verification simulator of the present invention are provided.
本発明によれば、プログラマブルコントローラのPID演算動作の検証を短時間で手間少なく、コスト安価に、かつ安全性を確保して実施することが可能となる。 ADVANTAGE OF THE INVENTION According to this invention, it becomes possible to verify the PID calculation operation of a programmable controller in a short time, with little effort, at low cost, and ensuring safety.
以下、添付した図面を参照して、本発明の実施の形態に係る検証シミュレータを説明すると、図1は、プログラマブルコントローラと、実施の形態の検証シミュレータと、を備えた検証システムを示す。図1に示す検証システムは、プログラマブルコントローラ1と、検証シミュレータ3とから構成されている。 Hereinafter, a verification simulator according to an embodiment of the present invention will be described with reference to the accompanying drawings. FIG. 1 shows a verification system including a programmable controller and a verification simulator according to the embodiment. The verification system shown in FIG. 1 includes a programmable controller 1 and a verification simulator 3.
プログラマブルコントローラ1は、目標値入力部5、現在値入力部7、PID演算部9、制御出力部11を備える。目標値入力部5はユーザにより設定される。制御対象が例えば電気炉であれば、目標値は電気炉内の目的温度である。現在値入力部7は、制御対象である電気炉内の現在温度である。PID演算部9は、目標値と現在値との偏差からPID演算を行うと共に、そのPID演算結果を制御出力部11に与える。制御出力部11はそのPID演算結果に対応した制御出力を検証シミュレータ3に出力する。この場合、検証シミュレータ3からプログラマブルコントローラ1の現在値入力部7に与えられる現在値はデジタルデータであり、また、プログラマブルコントローラ1から検証シミュレータ3に与えられる制御出力もデジタルデータである。
The programmable controller 1 includes a target
検証シミュレータ3は、マイクロコンピュータで構成することができるものであり、プログラマブルコントローラ1から入力されてくる制御出力を図3で示す実際の制御対象21の熱容量に対応した時間分遅らせて出力するバッファ部13と、このバッファ部13から出力される制御出力と制御対象の熱容量とに対応して現在値を演算してプログラマブルコントローラ1に制御対象の現在値として与える演算部15と、を備えている。
The verification simulator 3 can be composed of a microcomputer, and outputs a control output input from the programmable controller 1 with a delay corresponding to the actual heat capacity of the control target 21 shown in FIG. 13 and a
バッファ部13は、一例として、例えば縦続接続されたn個のシフトレジスタ131,132,…,13nで構成される。各シフトレジスタ131,132,…,13nはそれぞれ記憶素子で構成されている。このシフトレジスタ131,132,…,13nは初段のシフトレジスタ131に入力した制御出力を次段以降のシフトレジスタ132,…,13nに順次に単位時間tごとにシフトさせていき、終段のシフトレジスタ13nから演算部15に出力するよう構成されている。
As an example, the
図1で示す各段のシフトレジスタ131,132,…,13nにはプログラマブルコントローラ1から時間n×t前、(n−1)×t前、…、t前に出力された制御出力1,2,…,nが記憶保持されていることになる。したがって、バッファ部13から演算部15には時間n×t前の制御出力Voutが与えられることになる。
, 13n are control outputs 1, 2 output from the programmable controller 1 before time n × t, (n−1) × t,..., T before the
演算部15は、現在値をPV、制御出力をVout、時間をt、熱容量をCRとすると、現在値PVを増加させる場合はPV=Vout×[1−ε(-t/CR)] の式(1)で、現在値PVを減少させる場合はPV=Vout×[ε(-t/CR)]の式(2)で、それぞれ、現在値を演算するようになっている。 When the current value PV is increased, the current value PV is increased, assuming that the current value is PV, the control output is Vout, the time is t, and the heat capacity is CR, PV = Vout × [1-ε (−t / CR) ] In (1), when the current value PV is decreased, the current value is calculated by the equation (2) of PV = Vout × [ε (−t / CR) ].
制御対象である例えば電気炉ではプログラマブルコントローラ1から制御出力Voutが与えられても即座に応答して電気炉内の現在値PVが目標値になるのではなくその熱容量により遅れて現在値PVが増加または減少してくる。すなわち、制御出力Voutが大きくなると現在値PVは増加し、その増加割合は制御出力Voutの大きさに対応した上昇カーブを示し、制御出力Voutが小さくなると現在値PVは減少し、その減少割合は制御出力Voutの大きさに対応した下降カーブを示す。 In the electric furnace to be controlled, for example, even if the control output Vout is given from the programmable controller 1, the current value PV in the electric furnace does not become the target value in response immediately, but the current value PV increases with a delay due to its heat capacity. Or it will decrease. That is, when the control output Vout increases, the current value PV increases, and the increase rate shows a rising curve corresponding to the magnitude of the control output Vout. When the control output Vout decreases, the current value PV decreases, and the decrease rate is A descending curve corresponding to the magnitude of the control output Vout is shown.
この上昇、下降カーブは、制御対象である電気炉の熱容量をコンデンサと抵抗との直列充放電回路とみなし、その直列充放電回路におけるその充放電時定数CRにより定まるものと仮定できる。この場合、現在値PVが目標値より低い場合では現在値PVを増加させるため制御出力Voutが大きくなり、これによって現在値PVが増加する上昇カーブになり、現在値PVが目標値より高い場合では現在値PVを減少させるため制御出力Voutが小さくなり、これによって、現在値PVが減少する下降カーブになるが、そのカーブは上記熱容量に対応して応答遅れして変化する。 It can be assumed that the up and down curves are determined by the charge / discharge time constant CR in the series charge / discharge circuit, assuming that the heat capacity of the electric furnace to be controlled is a series charge / discharge circuit of a capacitor and a resistor. In this case, when the current value PV is lower than the target value, the control value Vout is increased in order to increase the current value PV. As a result, the current value PV is increased, and the current value PV is higher than the target value. Since the current value PV is decreased, the control output Vout is reduced, and as a result, the current value PV is decreased. The curve changes with a response delay corresponding to the heat capacity.
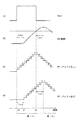
図2を参照して動作を説明する。図2(a)は制御出力Voutの変化、図2(b)は実際の制御対象を用いた場合のPIDプロセス制御による現在値PVの変化、図2(c)は実施の形態の検証シミュレータ3においてバッファ部13が無く、プログラマブルコントローラ1からの制御出力Voutを検証シミュレータ3の演算部15で演算した場合のPIDプロセス制御による現在値PVの変化、図2(d)は実施の形態の検証シミュレータ3においてバッファ部13により制御出力Voutを実際の制御対象と同等の応答遅れ条件で遅れさせて、検証シミュレータ3の演算部15で演算した場合のPIDプロセス制御による現在値PVの変化、をそれぞれ示す。
The operation will be described with reference to FIG. 2A shows the change in the control output Vout, FIG. 2B shows the change in the current value PV by the PID process control when an actual control target is used, and FIG. 2C shows the verification simulator 3 of the embodiment. In FIG. 2, the current value PV is changed by the PID process control when the control output Vout from the programmable controller 1 is calculated by the
図2(b)で示す実際の制御対象を用いたPIDプロセス制御による現在値PVの変化と比較しながら図2(a)と図2(d)とを中心に説明する。図2(c)は図2(d)との比較のために示しており、特に説明しない。 2A and 2D will be mainly described while comparing with the change in the current value PV by the PID process control using the actual control target shown in FIG. FIG. 2 (c) is shown for comparison with FIG. 2 (d) and will not be described in particular.
まず、図2(a)で示すようにプログラマブルコントローラ1からの制御出力Voutが時刻t0で大きく変化する。この制御出力Voutは検証シミュレータ3のバッファ部13内のシフトレジスタ13nに入力される。
First, as shown in FIG. 2A, the control output Vout from the programmable controller 1 changes greatly at time t0. The control output Vout is input to the
この制御出力Voutはバッファ部13内のn個のシフトレジスタ131,132,…,13n内を順次に単位時間tごとにクロックでシフトされていって演算部15に入力されるから、演算部15に入力されるまでには時間t×nを要することになる。
The control output Vout is sequentially shifted by the clock for each unit time t in the n shift registers 131, 132,..., 13n in the
すなわち、時刻t0でプログラマブルコントローラ1から与えられた制御出力Voutは、その時刻t0から時間t×n経過後の時刻t1で演算部15に入力されて上記式1で演算され、その演算結果が現在値PVとしてプログラマブルコントローラ1に入力される。
That is, the control output Vout given from the programmable controller 1 at time t0 is input to the
次に、この制御出力Voutは時刻tnまでは立ち下らないので、時刻tnになるまでは、時刻t1から順次に単位時間tだけ経過ごとにバッファ部13からの制御出力Voutが入力され演算部15で演算された現在値PVがプログラマブルコントローラ1に入力される。この場合、上記式(1)から現在値PVは図2(d)で示すような充放電時定数CRにより定まるカーブで上昇していく。
Next, since this control output Vout does not fall until time tn, the control output Vout from the
次に、図2(a)で示すように制御出力Voutが時刻tnで立ち下ると、図2(b)で示すように実際の現在値PVは時間t×n応答遅れして立ち下ってくる。すなわち、実施の形態では、その制御出力Voutは、検証シミュレータ3のバッファ部13により時間t×nだけ応答遅れして演算部15に入力されてから式(2)で演算されるので、その現在値PVは図2(d)で示すように立ち下ってくる。
Next, when the control output Vout falls at time tn as shown in FIG. 2A, the actual current value PV falls after a time t × n response delay as shown in FIG. 2B. . That is, in the embodiment, the control output Vout is calculated by the equation (2) after being input to the
以上から、図2(b)で示す実際の制御対象による現在値PVの上昇、下降カーブの形状に比較してバッファ部13で制御出力Voutを応答遅れさせないと図2(c)で示すような上昇、下降カーブとなり、図2(b)と一致しない。これに対して、実施の形態の検証シミュレータ3のバッファ部13で制御出力Voutを応答遅れさせた場合では、図2(a)の制御出力Voutに対して現在値PVは図2(d)で示すように実際の制御対象の図2(b)と一致した上昇、下降カーブとなる。
From the above, as shown in FIG. 2 (c), if the
以上から実施の形態では、検証シミュレータ3のバッファ部13により、プログラマブルコントローラ1からの制御出力を制御対象の熱容量に対応した時間分遅らせてから演算部15に入力するので、プログラマブルコントローラ1のPID演算動作が所要の設計通りであるか否かの検証を実施するに際して、ユーザが使用する可能性がある多品種の制御対象を想定したアプリケーションを製作する必要がなくなり、また、アプリケーションを動作させて検証を行う環境作りも特に必要としなくなり、さらに検証上の安全性も確保することができる。
From the above, in the embodiment, the
1 プログラマブルコントローラ
5 目標値入力部
7 現在値入力部
9 PID演算部
11 制御出力部
3 検証シミュレータ
13 バッファ部
15 演算部
DESCRIPTION OF SYMBOLS 1
Claims (4)
当該検証シミュレータは、
上記制御出力を入力すると共に、上記制御対象の熱容量に対応した時間分遅らせて出力するバッファ部と、
上記バッファ部から出力される制御出力と上記制御対象の熱容量とに対応して現在値を演算して上記プログラマブルコントローラに与える演算部と、
を備えたことを特徴とする検証シミュレータ。 The PID for a programmable controller with a PID process control function that performs a PID calculation based on a deviation between the target value and a current value that is a feedback value from the control target and outputs a control output corresponding to the PID calculation result to the control target. A verification simulator that is used in place of the control target to verify the process control function,
The verification simulator is
A buffer unit that inputs the control output and outputs a delayed time corresponding to the heat capacity to be controlled;
A calculation unit that calculates a current value corresponding to the control output output from the buffer unit and the heat capacity of the control target and gives the current value to the programmable controller;
A verification simulator characterized by comprising:
現在値PVを増加させる場合はPV=Vout×[1−ε(-t/CR)]
現在値PVを減少させる場合はPV=Vout×[ε(-t/CR)]
の式で現在値を演算することを特徴とする請求項1または2に記載の検証シミュレータ。 When the current value is PV, the control output is Vout, the time is t, and the heat capacity is CR,
When increasing the current value PV, PV = Vout × [1−ε (−t / CR) ]
PV = Vout × [ε (-t / CR) ] to decrease the current value PV
3. The verification simulator according to claim 1, wherein the current value is calculated by the following formula.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2007200425A JP2009037377A (en) | 2007-08-01 | 2007-08-01 | Verification simulator for programmable controller with pid process control function and verification system using the same |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2007200425A JP2009037377A (en) | 2007-08-01 | 2007-08-01 | Verification simulator for programmable controller with pid process control function and verification system using the same |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| JP2009037377A true JP2009037377A (en) | 2009-02-19 |
Family
ID=40439226
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2007200425A Pending JP2009037377A (en) | 2007-08-01 | 2007-08-01 | Verification simulator for programmable controller with pid process control function and verification system using the same |
Country Status (1)
| Country | Link |
|---|---|
| JP (1) | JP2009037377A (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2023017350A (en) * | 2021-07-26 | 2023-02-07 | 栗田工業株式会社 | control system |
Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH08179806A (en) * | 1994-12-27 | 1996-07-12 | Toshiba Corp | Internal model predictive controller |
| JP2004265001A (en) * | 2003-02-28 | 2004-09-24 | Omron Corp | Process control equipment and CPU unit |
-
2007
- 2007-08-01 JP JP2007200425A patent/JP2009037377A/en active Pending
Patent Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH08179806A (en) * | 1994-12-27 | 1996-07-12 | Toshiba Corp | Internal model predictive controller |
| JP2004265001A (en) * | 2003-02-28 | 2004-09-24 | Omron Corp | Process control equipment and CPU unit |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2023017350A (en) * | 2021-07-26 | 2023-02-07 | 栗田工業株式会社 | control system |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN103238122B (en) | The operational method of safety feature, safety feature | |
| JP2010281315A (en) | Method for controlling temperature of glow plug, and glow plug control unit | |
| CN109116881A (en) | A kind of temprature control method and system based on PID adjusting | |
| WO2009080282A3 (en) | Optimizing the operation of a power plant | |
| JP6356502B2 (en) | Equipment operation setting device and equipment operation setting value determination program | |
| JP2019101847A (en) | Control device and control method | |
| US9684287B2 (en) | Controlling device and controlling method | |
| CN110108124B (en) | A kind of roller kiln multi-stage temperature control method, device, equipment and storage medium | |
| JP2011090609A (en) | Temperature control device and temperature control method | |
| CN105988487B (en) | Control device and control method | |
| CN114115383A (en) | Method and system for controlling temperature of product in oven, electronic device and storage medium | |
| JP7109728B2 (en) | Power control device and power control method | |
| JP6922224B2 (en) | Control device, control method, control program | |
| JP5023821B2 (en) | Power control method and power control apparatus | |
| JP5125190B2 (en) | Phase control method and phase control apparatus | |
| JP5923416B2 (en) | Control device | |
| CN116126050A (en) | Oven heating control method and system, electronic device, storage medium | |
| Wright et al. | Two-degree-of-freedom output feedback controllers for discrete-time nonlinear systems | |
| JP2017062542A (en) | Control device and control method | |
| JP7525362B2 (en) | Control device and control method | |
| JP5062272B2 (en) | Temperature control system | |
| JP7028620B2 (en) | Control device and monitoring method | |
| JP4256236B2 (en) | Control apparatus and control method | |
| JP7025186B2 (en) | Control device and monitoring method | |
| JP6581830B2 (en) | Control apparatus and control method |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Effective date: 20100714 Free format text: JAPANESE INTERMEDIATE CODE: A621 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20110906 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20110907 |
|
| A02 | Decision of refusal |
Effective date: 20120110 Free format text: JAPANESE INTERMEDIATE CODE: A02 |