EP4535331A1 - Coordination device, roadside unit, movement control system, program, movement control method, and moving body - Google Patents
Coordination device, roadside unit, movement control system, program, movement control method, and moving body Download PDFInfo
- Publication number
- EP4535331A1 EP4535331A1 EP23819526.7A EP23819526A EP4535331A1 EP 4535331 A1 EP4535331 A1 EP 4535331A1 EP 23819526 A EP23819526 A EP 23819526A EP 4535331 A1 EP4535331 A1 EP 4535331A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- moving body
- unit
- prohibited section
- movement
- prohibited
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images






Classifications
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/09—Arrangements for giving variable traffic instructions
- G08G1/0962—Arrangements for giving variable traffic instructions having an indicator mounted inside the vehicle, e.g. giving voice messages
- G08G1/0967—Systems involving transmission of highway information, e.g. weather, speed limits
- G08G1/096708—Systems involving transmission of highway information, e.g. weather, speed limits where the received information might be used to generate an automatic action on the vehicle control
- G08G1/096725—Systems involving transmission of highway information, e.g. weather, speed limits where the received information might be used to generate an automatic action on the vehicle control where the received information generates an automatic action on the vehicle control
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/01—Detecting movement of traffic to be counted or controlled
- G08G1/0104—Measuring and analyzing of parameters relative to traffic conditions
- G08G1/0108—Measuring and analyzing of parameters relative to traffic conditions based on the source of data
- G08G1/0112—Measuring and analyzing of parameters relative to traffic conditions based on the source of data from the vehicle, e.g. floating car data [FCD]
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/01—Detecting movement of traffic to be counted or controlled
- G08G1/0104—Measuring and analyzing of parameters relative to traffic conditions
- G08G1/0108—Measuring and analyzing of parameters relative to traffic conditions based on the source of data
- G08G1/0116—Measuring and analyzing of parameters relative to traffic conditions based on the source of data from roadside infrastructure, e.g. beacons
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/01—Detecting movement of traffic to be counted or controlled
- G08G1/0104—Measuring and analyzing of parameters relative to traffic conditions
- G08G1/0125—Traffic data processing
- G08G1/0133—Traffic data processing for classifying traffic situation
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/09—Arrangements for giving variable traffic instructions
- G08G1/0962—Arrangements for giving variable traffic instructions having an indicator mounted inside the vehicle, e.g. giving voice messages
- G08G1/0967—Systems involving transmission of highway information, e.g. weather, speed limits
- G08G1/096766—Systems involving transmission of highway information, e.g. weather, speed limits where the system is characterised by the origin of the information transmission
- G08G1/096775—Systems involving transmission of highway information, e.g. weather, speed limits where the system is characterised by the origin of the information transmission where the origin of the information is a central station
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/20—Monitoring the location of vehicles belonging to a group, e.g. fleet of vehicles, countable or determined number of vehicles
- G08G1/207—Monitoring the location of vehicles belonging to a group, e.g. fleet of vehicles, countable or determined number of vehicles with respect to certain areas, e.g. forbidden or allowed areas with possible alerting when inside or outside boundaries
Definitions
- the present invention relates to a traffic control device, a roadside unit, a movement control system, a program, a movement control method, and a moving body.
- Patent document 1 is an example of this type of technology.
- Patent document 1 describes a device including: an acquisition means for acquiring automatic travel information which is information relating to a host vehicle and a state around the host vehicle; an automatic travel means for performing automatic travel by controlling a traveling direction and a speed of the host vehicle based on the automatic travel information; a determination means for determining whether or not a problem related to the automatic travel information has occurred; and a change means for changing, in the case of a problem occurring, a traveling state of the host vehicle or a traveling state of another vehicle in accordance with the content of the problem.
- Patent Document 1 Japanese Unexamined Patent Application, Publication No. 2016-181031
- an object of the present invention is to provide a traffic control device, a roadside unit, a movement control system, a program, and a movement control method that can support safe movement of a moving body with a simpler configuration and processing. Further, it is another object of the present invention to provide a moving body that is managed and controlled by the traffic control device.
- the moving body information acquisition unit 110 executes processing of acquiring information relating to the moving body 3 traveling in the communicable area of the roadside unit 1.
- the moving body information acquisition unit 110 includes the identification information acquisition unit 111, the positional information acquisition unit 112, and the travel information acquisition unit 113.
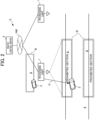
- the prohibited section A of the roadside unit 1 is formed in regions on both sides of the road 4 (regions on the road side and the periphery thereof).
- the prohibited section A on the lower side of the drawing shows the positional relationship of the prohibited section A on the road 4, and the prohibited section A and the moving body 3 on the upper side of the drawing virtually show the contents of the comparison processing of the positional information of the moving body 3 and the prohibited section A by the processing unit 10 described later.
- the prohibited section information includes information indicating an alarm area B set around the prohibited section A. That is, the alarm area B is an area in which there is a high possibility that the moving body 3 will move out of the prohibited section A when the moving body 3 continues to move. In the present embodiment, the alarm area B is provided so as to surround the prohibited section A in a plan view.
- the prohibited section information acquisition unit 120 executes processing of acquiring prohibited section information from the traffic control server 2 or the storage unit 11. In the present embodiment, when the prohibited section information is received from the traffic control server 2, the prohibited section information acquisition unit 120 updates the prohibited section information stored in the storage unit 11 to the received prohibited section information.
- the signal output processing unit 130 executes processing of outputting various signals for controlling the moving body 3 based on the positional information of the moving body 3 and the like.
- the signal output processing unit 130 includes a mode switching signal output processing unit 131, a prohibition signal output processing unit 132, and an alarm signal output processing unit 133.
- the mode switching signal output processing unit 131 executes processing of outputting the first mode switching signal based on the positional information of the moving body 3 and the prohibited section information.
- the first mode switching signal is a control signal including an instruction to perform mode switching for switching the mode in which the moving body 3 moves to the controlled mode or the non-controlled mode.
- the controlled mode refers to a mode in which the operation of the moving body 3 is controlled in accordance with a control signal such as a prohibition signal P or an alarm signal transmitted from the roadside unit 1.
- the non-controlled mode is a mode in which the operation of the moving body 3 is not controlled by a control signal such as the prohibition signal P or the alarm signal transmitted from the roadside unit 1.
- FIGS. 4A and 4B are diagrams for explaining the relationship between the control target area C and the prohibited section A.
- the prohibited section A is indicated by a one-dot chain line
- the control target area C is indicated by a broken line.
- the control target area C is set to be outside the entrance and the exit of the prohibited section A in the traveling direction of the moving body 3 on the road 4 and to be wider than the widths of the two prohibited sections A.
- the control target area C may be set to be at the same place as the entrance and the exit of the alarm area B existing around the prohibited section A and to be wider than the widths of the two prohibited sections A.
- the mode switching signal output processing unit 131 when it is determined that the moving body 3 has entered the control target area C based on the positional information of the moving body 3, the mode switching signal output processing unit 131 outputs a first mode switching signal for performing mode switching from the non-controlled mode to the controlled mode. In addition, when it is determined that the moving body 3 has exited the control target area C based on the positional information of the moving body 3, the mode switching signal output processing unit 131 outputs the first mode switching signal for executing mode switching from the controlled mode to the non-controlled mode.
- the prohibition signal output processing unit 132 executes processing of outputting the prohibition signal P for prohibiting the movement of the moving body 3 in the controlled mode.
- the prohibition signal output processing unit 132 compares the positional information of the moving body 3 with the prohibited section information, and outputs the prohibition signal P based on the comparison result. Specifically, the prohibition signal output processing unit 132 determines whether or not the moving body 3 exists in the prohibited section A based on the comparison result between the positional information of the moving body 3 and the prohibited section information, and outputs the prohibition signal P when it is determined that the moving body 3 exists in the prohibited section A.
- the prohibition signal output processing unit 132 may determine that the moving body 3 exists in the prohibited section A only when the entire moving body 3 is located in the prohibited section A by using the information relating to the size of the moving body 3, which is the identification information. For example, the prohibition signal output processing unit 132 may determine that the moving body exists in the prohibited section A when at least a part of the moving body 3 is located in the prohibited section A. Further, when the center of the vehicle body of the moving body 3 is located in the prohibited section A, it may be determined that the moving body 3 exists in the prohibited section A. For example, the moving body 3 receives control for restricting the continuous travel when the prohibition signal P is received in the controlled mode, and is allowed to perform the continuous travel when the prohibition signal P is not received.
- the alarm signal output processing unit 133 executes processing of outputting an alarm signal based on the positional information of the moving body 3 and the prohibited section information.
- the alarm signal refers to a control signal including an instruction to cause the moving body 3 to perform processing of generating an alarm that alerts the operator of the moving body 3.
- the alarm signal output processing unit 133 compares the positional information with the information indicating the alarm area B included in the prohibited section information, and determines whether or not the moving body 3 exists in the alarm area B based on the comparison result. When it is determined that the moving body 3 exists in the alarm area B, the alarm signal output processing unit 133 outputs an alarm signal indicating that the moving body 3 exists in the alarm area B to the moving body 3.
- FIG. 5 is a block diagram illustrating a configuration of hardware and functional blocks of the traffic control server 2.
- the traffic control server 2 includes a processing unit 20, a storage unit 21, and a communication I/F 22.
- the processing unit 20 is an arithmetic device configured by a processor such as a CPU, and reads and executes various programs and data from the storage unit 21 described later to realize a function of movement control.
- the processing unit 20 executes data processing of each functional unit of a roadside unit information acquisition unit 210, a map information management unit 220, a prohibited section information management unit 230, and a mode switching signal output processing unit 240.
- the operation of each functional unit will be described later.
- the function of the movement control of the processing unit 20 may be realized by hardware or software.
- the storage unit 21 is a storage area for various programs for causing a hardware group to function as the traffic control server 2, various data, and the like, and can be configured by ROM, RAM, flash memory, a semiconductor drive (SSD), hardware (HDD), or the like.
- the storage unit 21 stores a program for causing the processing unit 20 to execute each function of the present embodiment, a control program of the traffic control server 2, various parameters, data used for movement control of the moving body 3, identification information such as IP addresses and MAC addresses of a plurality of roadside units 1 communicably connected to the traffic control server 2, geographical map information including communicable areas of the plurality of roadside units 1, and prohibited section information in each communicable area of the plurality of roadside units 1.
- the communication I/F 22 is an interface for the traffic control server 2 to communicate via the communication network NW.
- the traffic control server 2 is communicably connected to the plurality of roadside units 1 and other communication devices via the communication I/F 22.
- the roadside unit information acquisition unit 210 executes processing of acquiring roadside unit information transmitted from each of the plurality of roadside units 1.
- Examples of the roadside unit information include moving body information acquired by each of the plurality of roadside units 1, information relating to an event occurring on the road 4, and information relating to an output state of various control signals by the roadside unit 1.
- Examples of the information relating to the event include a traffic accident, traffic congestion, a breakdown of a vehicle, traveling of an emergency vehicle, a road surface abnormality, a fire, traveling of a maintenance vehicle on the road 4, and the like.
- the roadside unit information acquisition unit 210 acquires information such as identification information, positional information, and travel information of the moving body 3 traveling in the communicable area of each roadside unit 1, information relating to the occurrence situation of a traffic accident on the road 4, and the like.
- Examples of the information relating to the output status of the various control signals include the presence or absence of the output of the first mode switching signal, the alarm signal, the prohibition signal P, and the like.
- the map information management unit 220 generates map information based on information acquired from the outside and updates the map information as needed.
- the map information may be, for example, a dynamic map.
- the dynamic map is a combination of static information such as road surface information, lane information, and structures, and dynamic information such as traffic regulations, construction, congestion, vehicles, pedestrians, and signals, and is a three-dimensional digital map having latitude, longitude, and altitude information.
- the map information management unit 220 updates the dynamic map as needed based on information acquired from the outside, and transmits the dynamic map to each of the plurality of roadside units 1.
- the map information transmitted to each roadside unit 1 is transmitted from the roadside unit 1 to the moving body 3 while traveling.
- the prohibited section information management unit 230 executes processing of generating and managing prohibited section information for each of the plurality of roadside units 1. Specifically, the prohibited section information management unit 230 generates prohibited section information for each of the plurality of roadside units 1 based on information acquired via the communication network NW or a predetermined program stored in the storage unit 21. Then, the prohibited section information management unit 230 transmits the generated prohibited section information to the corresponding roadside unit 1.
- the prohibited section information management unit 230 may generate different prohibited section information depending on, for example, a time period.
- the prohibited section information management unit 230 may provide the prohibited section A on the road side of the road 4, and may set the size of the prohibited section A in a time period such as the morning or evening when children go (back) to school (hereinafter, referred to as a school time period) to be larger than other time periods. Further, for example, the prohibited section information management unit 230 may provide the prohibited section A only in the school time period. The prohibited section information management unit 230 may generate different prohibited section information based on information acquired from the outside. For example, the prohibited section information management unit 230 may change the prohibited section information based on the information relating to the event acquired from the roadside unit 1.
- the prohibited section information management unit 230 may generate the prohibited section information indicating the prohibited section A provided at and around the accident occurrence location. Further, for example, when acquiring information indicating that a maintenance vehicle is traveling on an expressway, the prohibited section information management unit 230 may generate the prohibited section information for the maintenance vehicle to move.
- the mode switching signal output processing unit 240 executes processing of outputting a second mode switching signal (operation mode switching signal).
- the second mode switching signal refers to a control signal including a command to execute driving mode switching for switching the driving mode of the moving body 3 to the autonomous driving mode or the remote driving mode.
- the mode switching signal output processing unit 240 may output the second mode switching signal based on the output state of the prohibition signal P by the signal output processing unit 130 of the roadside unit 1, for example. Specifically, in a case where it is determined that the prohibition signal P is outputted from the roadside unit 1, the mode switching signal output processing unit 240 may output the second mode switching signal to execute driving mode switching for switching the driving mode of the moving body 3 from the autonomous driving mode to the remote driving mode.
- the mode switching signal output processing unit 240 may output the second mode switching signal to execute driving mode switching for switching the driving mode of the moving body 3 from the remote driving mode to the autonomous driving mode, for example.
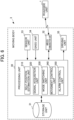
- FIG. 6 is a block diagram illustrating the configuration of hardware and functional blocks of the moving body 3.
- the moving body 3 includes the processing unit 30, the storage unit 31, the wireless communication unit 32, the sensor unit 33, the GNSS unit 34, and the driving unit 35.
- the processing unit 30 is an arithmetic device configured by a processor such as a CPU, and reads and executes various programs and data from the storage unit 31 described later to realize a function of movement control.
- the processing unit 30 executes data processing of each functional unit of a self-position estimation unit 310, a signal acquisition unit 320, a mode switching unit 330, a movement control unit 340, and an alarm control unit 350. The operation of each functional unit will be described later.
- the storage unit 31 is a storage area for various programs and various data for causing a hardware group to function as the moving body 3, and can be configured by ROM, RAM, flash memory, a semiconductor drive (SSD), hardware (HDD), or the like. Specifically, the storage unit 31 stores a program (a control program of the moving body 3) for causing the processing unit 30 to execute each function of the present embodiment, various parameters, data used for movement control of the moving body 3, identification information such as an identification ID and an IP address of the moving body 3, map information, and the like. Examples of the map information include a dynamic map.
- the wireless communication unit 32 executes processing for the moving body 3 to wirelessly communicate with the roadside unit 1.
- the wireless communication unit 32 transmits, for example, identification information for identifying the moving body 3, positional information indicating the position of the moving body 3, travel information of the moving body 3, and the like to the roadside unit 1, and receives various control signals such as the first mode switching signal, the prohibition signal P, and the alarm signal, the map information generated by the traffic control server 2, and the like from the roadside unit 1.
- the wireless communication unit 32 communicates with the processing unit 10 via the wireless communication unit 13 of the roadside unit 1.
- the sensor unit 33 is a device for detecting information relating to the surroundings of the moving body 3 itself.
- the sensor unit 33 may be, for example, radar or LIDAR (light detection and ranging) that detects a distance, a direction, a relative speed, or the like relative to an object present around the moving body 3 based on a transmission wave transmitted to the periphery of the moving body 3 and a reflected received wave, or may be a camera or the like.
- LIDAR is used which irradiates laser light around the moving body 3 and detects a surrounding object as point cloud data. According to LIDAR, it is possible to detect the position, the shape, and the like of the surrounding object with high accuracy.
- the sensor unit 33 transmits the detected point cloud data to the processing unit 30.
- the GNSS (Global Navigation Satellite System) unit 34 includes an antenna and receives a GNSS signal and the like.
- the GNSS signal is transmitted from a navigation satellite or the like that make up a GNSS such as GPS (Global Positioning System) or a quasi-zenith satellite system.
- the GNSS unit 34 transmits the received GNSS signal to the processing unit 30.
- the driving unit 35 is a part related to driving of the moving body 3, such as an engine, a motor, or a brake.
- the self-position estimation unit 310 executes processing of estimating positional information indicating the position of the moving body 3 itself.
- the self-position estimation unit 310 may estimate the positional information of the moving body 3 based on the map information received from the traffic control server 2, the point cloud data around the moving body 3 received from the sensor unit 33, the GNSS signal received from the GNSS unit 34, and the like. More specifically, the self-position estimation unit 310 may estimate the positional information of the moving body 3 by collating the map information with the point cloud data around the moving body 3.
- the positional information estimated by the self-position estimation unit 310 is transmitted to the roadside unit 1 via the wireless communication unit 32.
- the signal acquisition unit 320 executes processing of acquiring various control signals such as the first mode switching signal, the second mode switching signal, the prohibition signal P, and the alarm signal from the roadside unit 1 via the wireless communication unit 32.
- the mode switching unit 330 switches the movement mode of the moving body 3. Specifically, when the first mode switching signal for executing mode switching from the non-controlled mode to the controlled mode is acquired in a state where the movement mode of the moving body 3 is the non-controlled mode, the mode switching unit 330 switches the movement mode to the controlled mode. On the other hand, when the first mode switching signal for performing mode switching from the controlled mode to the non-controlled mode is acquired in a state where the movement mode of the moving body 3 is the controlled mode, the mode switching unit 330 switches the movement mode from the controlled mode to the non-controlled mode.
- the mode switching unit 330 switches the operation mode of the moving body 3. Specifically, when the second mode switching signal is acquired in a state where the driving mode of the moving body 3 is the autonomous driving mode, the mode switching unit 330 switches the driving mode to the remote driving mode. Conversely, when the second mode switching signal is acquired in a state where the driving mode of the moving body 3 is the remote driving mode, the mode switching unit 330 switches the driving mode from the remote driving mode to the autonomous driving mode.
- the movement control unit 340 executes processing of controlling the movement of the moving body 3 based on the positional information, etc. estimated by the self-position estimation unit 310. Specifically, the movement control unit 340 controls the movement to the set destination by controlling the driving of the driving unit 35 based on the positional information and the travel information of the moving body 3, the map information stored in the storage unit 31, and the like.
- the movement control unit 340 stops the autonomous driving and executes processing of controlling the movement of the moving body 3 based on the remote operation signal.
- the remote control signal may be transmitted to the moving body 3 via the communication network NW from a facility such as a traffic control center having, for example, the traffic control server 2.
- the remote control signal may be generated as a signal such that the moving body 3 moves to the outside of the prohibited section A based on, for example, the positional information of the moving body 3 or the map information acquired via the traffic control server 2, the prohibited section information, the image captured by the moving body 3 or the roadside unit 1, or the like.
- the movement control unit 340 executes processing of controlling the driving of the moving body 3 based on the acquisition status of the prohibition signal P by the signal acquisition unit 320.
- the prohibition signal P transmitted from the processing unit 10 of the roadside unit 1 is received by the wireless communication unit 32, the movement control unit 340 controls the driving unit 35 to perform an operation corresponding to the prohibition signal P.
- the operation corresponding to the prohibition signal P refers to, for example, an operation of stopping the driving of the moving body 3 or an operation for the moving body 3 to leave from the prohibited section A.
- the movement control unit 340 may execute control for stopping the moving body 3, and may control the moving body 3 so that the moving body 3 in the prohibited section A leaves the prohibited section A.
- the control for stopping the moving body 3 may be, for example, control for stopping the moving body 3 after decelerating to a predetermined speed.
- the movement control unit 340 may execute control for stopping the moving body 3 or control for leaving the prohibited section A.
- the alarm control unit 350 executes processing for generating an alarm.
- the alarm may be audio information, textual information, or the like to inform the operator of the moving body 3 of the possibility of entering the prohibited section A.
- the alarm control unit 350 may display an alarm on a liquid crystal display or a mirror disposed in the moving body 3 or may generate audio information from a speaker disposed in the moving body 3.
- the moving body 3 is traveling between two prohibited sections A on the road 4.
- the prohibition signal output processing unit 132 of the roadside unit 1 the moving body 3 is located outside the prohibited section A, and thus the prohibition signal P is not outputted. Therefore, the moving body 3 is continuously running.
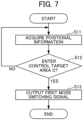
- FIG. 7 is a flowchart showing an example of processing up to the output of the first mode switching signal in the movement control executed by the processing unit 10 of the roadside unit 1
- FIG. 8 is a flowchart showing an example of processing for controlling the moving body 3 in the controlled mode.
- the processing unit 10 executes the processing of FIGS. 7 and 8 based on, for example, a program stored in the storage unit 11 or the like.
- the flows of the processing exemplified in FIGS. 7 and 8 each start the processing when the installed roadside unit 1 is activated, and then continue the processing during the operation of the roadside unit 1.
- step S11 the positional information acquisition unit 112 acquires the positional information of the moving body 3 received via the wireless communication unit 13.
- step S12 the mode switching signal output processing unit 131 compares the positional information acquired in step S11 with the information indicating the position of the control target area C stored in the storage unit 11, and determines whether the moving body 3 has entered the control target area C. When it is determined that the moving body 3 has entered the control target area C (step S12; YES), the mode switching signal output processing unit 131 proceeds to step S13. On the other hand, when it is determined that the moving body 3 is located outside the control target area C (step S12; NO), the mode switching signal output processing unit 131 repeats the processing of step S11.
- step S13 the mode switching signal output processing unit 131 outputs the first mode switching signal for switching the moving body 3 to the controlled mode. Then, the first mode switching signal is transmitted to the moving body 3 by the wireless communication unit 13.
- step S21 the prohibited section information acquisition unit 120 extracts the prohibited section information from the storage unit 11.
- step S22 the positional information acquisition unit 112 acquires the positional information of the moving body 3 received via the wireless communication unit 13.
- step S23 the prohibition signal output processing unit 132 compares the prohibited section information acquired in step S21 with the positional information acquired in step S22, and determines whether or not the moving body 3 is located within the prohibited section A.
- step S23; YES the processing proceeds to step S24.
- step S23; NO the processing of step S22 is repeated.
- step S24 the prohibition signal output processing unit 132 outputs the prohibition signal P for prohibiting the movement of the moving body 3 in the prohibited section A. Then, the prohibition signal P is transmitted to the moving body 3 by the wireless communication unit 13. Thereafter, the processing unit 10 returns the processing to step S22.
- FIG. 9 is a flowchart illustrating an example of processing of the movement control executed by the processing unit 20 of the traffic control server 2.
- the processing unit 20 executes the processing of FIG. 9 based on, for example, a program stored in the storage unit 21 or the like.
- the flow of processing illustrated in FIG. 9 starts the processing when the traffic control server 2 installed is activated, and then continues the processing while the traffic control server 2 is operating.
- the roadside unit information acquisition unit 210 acquires roadside unit information that is transmitted from each of the plurality of roadside units 1, and includes the output status of the prohibition signal P by each of the roadside units 1 and the positional information of the moving body 3.
- step S32 the mode switching signal output processing unit 240 determines whether or not the prohibition signal P is outputted by the roadside unit 1 based on the roadside unit information acquired in step S31.
- the mode switching signal output processing unit 240 causes the processing to proceed to step S33.
- the mode switching signal output processing unit 240 returns the processing to step S31.
- step S33 the mode switching signal output processing unit 240 outputs the second mode switching signal. Then, the second mode switching signal is transmitted to the moving body 3 via the roadside unit 1 and the wireless communication unit 13 which outputted the prohibition signal P.
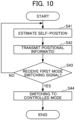
- FIG. 10 is a flowchart showing an example of processing executed by the moving body 3 until the movement mode is switched to the controlled mode
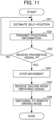
- FIG. 11 is a flowchart showing an example of processing executed by the moving body 3 in the controlled mode. It is to be noted that the moving body 3 at the start of the flow of FIG. 10 assumes that the movement mode is the non-controlled mode and the driving mode is the autonomous driving mode.
- the self-position estimation unit 310 estimates the positional information indicating the position of the moving body 3 itself.
- the self-position estimation unit 310 estimates the positional information of the moving body 3 itself based on, for example, the map information received from the traffic control server 2 via the roadside unit 1 and point cloud data received from the sensor unit 33.
- step S42 the wireless communication unit 32 transmits the positional information of the moving body 3 estimated in step S41 to the roadside unit 1.
- step S43 the mode switching unit 330 determines whether or not the first mode switching signal has been received from the roadside unit 1. When it is determined that the first mode switching signal has been acquired by the signal acquisition unit 320 (step S43; YES), the mode switching unit 330 causes the processing to proceed to step S44. On the other hand, when it is determined that the signal acquisition unit 320 has not acquired the first mode switching signal (step S43; NO), the mode switching unit 330 returns the processing to step S31.
- step S44 the mode switching unit 330 switches the movement mode of the moving body 3 to the controlled mode.
- the self-position estimation unit 310 estimates the positional information indicating the position of the moving body 3 itself.
- the self-position estimation unit 310 estimates the positional information of the moving body 3 itself based on, for example, the map information received from the traffic control server 2 via the roadside unit 1 and point cloud data received from the sensor unit 33.
- step S52 the wireless communication unit 32 transmits the positional information of the moving body 3 estimated in step S51 to the roadside unit 1.
- step S53 the movement control unit 340 determines whether or not the signal acquisition unit 320 has received the prohibition signal P.
- the movement control unit 340 causes the processing to proceed to step S54.
- the movement control unit 340 returns the processing to step S51.
- step S54 the movement control unit 340 controls the driving unit 35 to stop the movement of the moving body 3.
- step S55 the processing unit 30 receives the second mode switching signal from the traffic control server 2. Then, the mode switching unit 330 switches the driving mode of the moving body 3 from the autonomous driving mode to the remote driving mode.
- the processing unit 10 includes the positional information acquisition unit 112 that acquires positional information indicating the position of the moving body 3, and the signal output processing unit 130 that compares the positional information with the prohibited section information indicating the prohibited section A in which the movement of the moving body 3 is prohibited, and outputs the prohibition signal P that prohibits the movement of the moving body 3 in the prohibited section A based on the result of the comparison.
- the signal output processing unit 130 determines whether the moving body 3 exists in the prohibited section A based on the result of the comparison, and when it is determined that the moving body 3 exists in the prohibited section A, outputs the prohibition signal P.
- the prohibited section information includes information indicating the alarm area B set around the prohibited section A
- the signal output processing unit 130 determines whether the moving body 3 exists in the alarm area B based on a result of the comparison, and when it is determined that the moving body 3 exists in the alarm area B, outputs an alarm signal for causing the moving body 3 to execute the processing whereby the moving body 3 generates an alarm.
- the moving body 3 is the moving body 3 which is configured to move autonomously. With such a configuration, even if an abnormality occurs in the traveling of the self-driving vehicle, it is possible to suppress the traveling of the self-driving vehicle in the prohibited section A.
- the roadside unit 1 is the roadside unit 1 which includes each constituent element of the processing unit 10, and is installed on the road 4 on which the moving body 3 moves or at the roadside of the road 4. With such a configuration, it is possible to assist in the safe movement of the moving body 3 traveling on the road 4 by a simple configuration and processing.
- the movement control system S is configured to be able to perform wireless communication with the moving body 3, and includes the plurality of roadside units 1 each installed in a different area, and the traffic control server 2 communicably connected to the plurality of roadside units 1.
- the traffic control server 2 includes the prohibited section information management unit 230 that generates the prohibited section information indicating the prohibited section A in which the movement of the moving body 3 is prohibited and transmits the prohibited section information to each of the plurality of roadside units 1.
- the roadside unit 1 includes the positional information acquisition unit 112 that acquires positional information indicating the position of the moving body 3 and the signal output processing unit 130 that compares the positional information with the prohibited section information received from the traffic control server 2 and outputs the prohibition signal P that prohibits the movement of the moving body 3 in the prohibited section A based on a result of the comparison.
- the signal output processing unit 130 determines whether the moving body 3 exists in the prohibited section A based on the result of the comparison, and when it is determined that the moving body 3 exists in the prohibited section A, outputs the prohibition signal P. With such a configuration, it is possible to prevent the moving body 3 from moving in an area where there is a risk of danger, by simple processing of comparing the position of the moving body 3 with the prohibited section A.
- the prohibited section A in an area including the oncoming lane, the road side, and the sidewalk of the road 7, it is possible to prevent the moving body 3 from entering the area and causing an accident if an abnormality occurs in the control of the self-driving vehicle or if an elderly driver erroneously performs a driving operation. Therefore, it is possible to assist in the safe movement of the moving body 3 with a simple configuration and processing.
- the prohibited section information includes information indicating the alarm area B set around the prohibited section A
- the signal output processing unit 130 of the roadside unit 1 determines whether the moving body 3 exists in the alarm area B based on the result of the comparison, and when it is determined that the moving body 3 exists in the alarm area B, outputs an alarm signal for causing the moving body 3 to perform processing of generating an alarm.
- the prohibited section information management unit 230 of the traffic control server 2 generates the prohibited section information which varies depending on a time period.
- the moving body 3 is a moving body 3 that is configured to move autonomously. With such a configuration, even if an abnormality occurs in the traveling of the self-driving vehicle, it is possible to suppress the traveling of the self-driving vehicle in the prohibited section A.
- the moving body 3 has driving modes including the autonomous driving mode in which the vehicle autonomously travels along a set travel route and the remote driving mode in which the vehicle travels based on a remote operation signal for remotely operating the moving body 3.
- the traffic control server 2 further includes the mode switching signal output processing unit 240 that outputs a driving mode switching signal for switching the driving mode of the moving body 3 to the remote driving mode when the prohibition signal P is outputted by the signal output processing unit 130.
- the program according to the present embodiment causes a computer included in the roadside unit 1 to execute: a positional information acquisition function of acquiring positional information indicating a position of the moving body 3; and a signal output processing function of comparing the positional information with prohibited section information indicating the prohibited section A in which the movement of moving body 3 is prohibited, and outputting the prohibition signal P for prohibiting the movement of moving body 3 in the prohibited section A based on a result of the comparison.
- the signal output processing function determines whether the moving body 3 exists in the prohibited section A based on the result of the comparison and, when it is determined that the moving body 3 exists in the prohibited section A, outputs the prohibition signal P.
- a movement control method is a movement control method executed by a roadside unit 1, and the method includes: a positional information acquisition step of acquiring positional information indicating a position of the moving body 3; and a signal output processing step of comparing the positional information with prohibited section information indicating the prohibited section A in which the movement of moving body 3 is prohibited, and outputting the prohibition signal P for prohibiting the movement of the moving body 3 based on a result of the comparison.
- the signal output processing step determines whether the moving body 3 exists in the prohibited section A based on the result of the comparison, and when it is determined that the moving body 3 exists in the prohibited section A, the signal output processing step outputs the prohibition signal P.
- the moving body 3 includes the wireless communication unit 32 that communicates with the processing unit 10, the self-position estimation unit 310 that estimates a self-position, the driving unit 35, and the movement control unit 340 that controls driving of the driving unit 35.
- the self-position estimation unit 310 transmits the estimated self-positional information to the processing unit 10 using the wireless communication unit 32.
- the movement control unit 340 controls the driving unit 35 to perform operation corresponding to the prohibition signal P when the movement control unit 340 receives the prohibition signal P transmitted from the processing unit 10 using the wireless communication unit 32.
- the moving body 3 in the above embodiment is a self-driving vehicle, it may be a vehicle that does not have an autonomous driving function. Further, the vehicle may be a four-wheeled motor vehicle or a two-wheeled motor vehicle. Also, the moving body 3 is not limited to vehicles and may be an unmanned flying object, such as a drone. In particular, in a case of an unmanned flying object, 3D map information made mainly using latitude, longitude, and altitude information is used.
- FIG. 12 is a schematic diagram illustrating an example of a flight path of an unmanned flying object to which the movement control system S according to a modification of the present embodiment is applied.
- the unmanned flying object is used for checking the state of electric wires 51 suspended by a steel tower 50, checking the state of a road or a wall surface in a tunnel, checking the state of a structure bridging over a river, a canal, a railway line, a road, or the like, checking a building, monitoring a river, a cliff, or a sea, and the like during a disaster.
- the state of the electric wires 51 of the steel tower 50 is inspected using an autonomously movable unmanned flying object.
- the prohibited section A in which the unmanned flying object can fly is defined by latitude, longitude, and altitude.
- the shape of the prohibited section A is a prismatic shape, but is not limited to this shape, and various shapes such as a cylindrical shape can be considered.
- the prohibited section A is set so as to surround the steel tower 50 and the electric wires 51.
- roadside units 1D, 1E, and 1F manage the prohibited section A.
- Each of the roadside units 1D, 1E, and 1F acquires the positional information from the unmanned flying object, compares the prohibited section information indicating the prohibited section A stored therein with the positional information of the unmanned flying object, and transmits the prohibition signal P to the unmanned flying object in a case in which the unmanned flying object is flying in the prohibited section A.
- a drone autonomous evacuation program for landing outside the prohibited section A on a safe route may be operated, or an emergency landing on the side opposite to the steel tower 50 may be performed. This makes it possible to prevent the unmanned flying object from coming into contact with the steel tower 50 and the electric wires 51 during inspection of the electric wires 51.
- the moving body 3 may also be a working robot.
- a prohibited section as an entry prohibited section may be set using 3D map information including information of latitude, longitude, and altitude.
- the moving body 3 can set a V2X communication terminal of a pedestrian or worker, also called V2P (Vehicle-to-Pedestrian) as its target.
- V2P Vehicle-to-Pedestrian
- each of the roadside units 1 includes the signal output processing unit 130, but the traffic control server 2 may acquire the positional information of the moving body 3 via each of the roadside units 1, and output the first mode switching signal, the prohibition signal P, and the alarm signal based on the comparison between the positional information and the prohibited section information.
- the traffic control server 2 outputs the second mode switching signal for switching the operation mode of the moving body 3, but each of the roadside units 1 may output the mode switching signal for switching the operation mode of the moving body 3 between the autonomous driving mode and the remote driving mode.
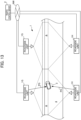
- FIG. 13 is a schematic diagram illustrating a movement control system S according to a modification of the present embodiment and an example of a road 4 to which the movement control system S is applied.
- the movement control system S includes a plurality of roadside units 1 including roadside units 1G and 1H which are installed on the road 4, or around or in the vicinity of the road 4 such as at the roadside of the road 4, and are capable of performing wireless communication with the moving body 3, which is a vehicle traveling on the road 4, and a traffic control server 2 communicably connected to each of the plurality of roadside units 1 via a communication network NW.
- the roadside units 1G and the roadside units 1H have the same configuration.
- the plurality of roadside units 1G are disposed at predetermined intervals along the road 4. Each of the roadside units 1H is disposed at a position opposite to a corresponding one of the roadside unit 1G across the road 4. Further, the plurality of roadside units 1G and the plurality of roadside units 1H may be disposed along the road 4 so as to cover the entire length of the prohibited section A, or one or a plurality of roadside units 1G and 1H may be disposed along the road 4 only at a specific place.
- the specific place refers to, for example, any place designated by the operator, such as a construction site.
- the prohibited section A of each of the plurality of roadside units 1 is set in such a manner that the entire prohibited sections A are overlapped with each other, but the present invention is not limited thereto, and the prohibited section A of each of the plurality of roadside units 1 is set in such a manner that the prohibited sections A are partially overlapped with each other.
- the moving body 3 when the moving body 3 is located in the overlapping prohibited sections A, the moving body 3 receives a plurality of prohibition signals P.
- the wireless communication unit 32 of the moving body 3 receives a plurality of prohibition signals P relating to movement into the same prohibited section A from different roadside units 1.
- the moving body 3 transmits the positional information to each of the roadside units 1G and the roadside units 1H.
- the roadside unit 1G transmits the positional information received from the moving body 3 to the traffic control server 2.
- the roadside unit 1H transmits the positional information received from the moving body 3 to the traffic control server 2.
- the traffic control server 2 generates a prohibition signal PG if the moving body 3 exists in the prohibited section A based on the positional information received from the roadside unit 1G, and transmits the generated prohibition signal PG to the roadside unit 1G. Then, the roadside unit 1G transmits the prohibition signal PG to the moving body 3. In addition, the traffic control server 2 generates a prohibition signal PH if the moving body 3 exists in the prohibited section A based on the positional information received from the roadside unit 1H, and transmits the generated prohibition signal PH to the roadside unit 1H. Then, the roadside unit 1H transmits the prohibition signal PH to the moving body 3.
- the wireless communication unit 32 of the moving body 3 receives the plurality of prohibition signals P related to restriction of movement into the same prohibited section A from different processing units 10.
- the wireless communication unit 32 receives, from the roadside unit 1G and the roadside unit 1H, the prohibition signals P related to restriction of movement into the same prohibited section A.
- the prohibition signal P may be generated by the roadside unit 1.
- the traffic control server 2 transmits, to each roadside unit 1 at a predetermined timing, information of the latest prohibited section A adapted to the place where each roadside unit 1 is disposed. Based on the positional information received from the moving body 3, the roadside unit 1G and the roadside unit 1H each generate the prohibition signal P if the moving body 3 exists in the prohibited section A, and transmit the generated prohibition signal P to the moving body 3.
- the movement control unit 340 of the moving body 3 may control the driving unit 35 to perform operation corresponding to the prohibition signals P. Specifically, when the predetermined number is "1", the movement control unit 340 of the moving body 3 controls the driving unit 35 to be driven when the prohibition signal PG or the prohibition signal PH is received. When the predetermined number is "2", the movement control unit 340 of the moving body 3 may control the driving unit 35 to be driven when the prohibition signal PG and the prohibition signal PH are received.
- each of the roadside units 1 is disposed at a position opposite to a corresponding one of the roadside unit 1 across the road 4, even when, for example, the moving body 3 runs in parallel with a large-sized moving body (for example, a truck or the like), it is possible for the movement control system S to reliably acquire the positional information of the moving body 3, which is the target, by the roadside unit 1 disposed on one side, and achieve a blind spot countermeasure.
- a large-sized moving body for example, a truck or the like
- the movement control system S since the plurality of roadside units 1 are disposed at different positions with respect to the same prohibited section A, even when any one of the roadside units 1 fails, it is still possible for the movement control system S to reliably acquire the positional information of the target moving body 3 by another roadside unit 1, and achieve a countermeasure against the failure of the device.
Landscapes
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Chemical & Material Sciences (AREA)
- Analytical Chemistry (AREA)
- Life Sciences & Earth Sciences (AREA)
- Atmospheric Sciences (AREA)
- Traffic Control Systems (AREA)
Abstract
Description
- The present invention relates to a traffic control device, a roadside unit, a movement control system, a program, a movement control method, and a moving body.
- Conventionally, a device for controlling the movement of a moving body has been known.
Patent document 1 is an example of this type of technology.Patent document 1 describes a device including: an acquisition means for acquiring automatic travel information which is information relating to a host vehicle and a state around the host vehicle; an automatic travel means for performing automatic travel by controlling a traveling direction and a speed of the host vehicle based on the automatic travel information; a determination means for determining whether or not a problem related to the automatic travel information has occurred; and a change means for changing, in the case of a problem occurring, a traveling state of the host vehicle or a traveling state of another vehicle in accordance with the content of the problem. - Patent Document 1:
Japanese Unexamined Patent Application, Publication No. 2016-181031 - However, the device described in
Patent document 1 requires a high-performance and expensive device capable of appropriately determining an abnormal state of a moving body. Therefore, in a case where a high-performance control device cannot be installed on a moving body due to cost constraints, the abnormal state of the moving body cannot be appropriately determined due to insufficient redundancy or insufficient calculation capability of the control device, and there is a possibility that the moving body cannot be safely moved. - In view of these circumstances, an object of the present invention is to provide a traffic control device, a roadside unit, a movement control system, a program, and a movement control method that can support safe movement of a moving body with a simpler configuration and processing. Further, it is another object of the present invention to provide a moving body that is managed and controlled by the traffic control device.
-
- (1) A traffic control device includes: a positional information acquisition unit that acquires positional information indicating a position of a moving body; and a signal output processing unit that compares the positional information with prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section, in which the signal output processing unit determines whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputs the prohibition signal.
- (2) In the traffic control device as described in (1), the prohibited section information includes information indicating an alarm area set around the prohibited section, and the signal output processing unit determines whether the moving body exists in the alarm area based on a result of the comparison, and when it is determined that the moving body exists in the alarm area, outputs an alarm signal that causes the moving body to execute processing of generating an alarm.
- (3) In the traffic control device as described in (1), the moving body is a moving body that is configured to move autonomously.
- (4) A roadside unit includes each component of the traffic control device as described in any one of (1) to (3) above, and the roadside unit is installed on a road on which the moving body moves or on a roadside of the road.
- (5) A movement control system is configured to wirelessly communicate with a moving body, and the movement control system includes: a plurality of first traffic control devices each installed in a different area; and a second traffic control device that is communicably connected to the plurality of first traffic control devices, in which the second traffic control device includes a prohibited section information management unit that generates prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and transmits the prohibited section information to each of the plurality of first traffic control devices, the first traffic control device includes a positional information acquisition unit that acquires positional information indicating a position of the moving body, and a signal output processing unit that compares the positional information with the prohibited section information received from the second traffic control device, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section, and the signal output processing unit determines whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputs the prohibition signal.
- (6) In the movement control system as described in (5), the prohibited section information includes information indicating an alarm area set around the prohibited section, and the signal output processing unit of the first traffic control device determines whether the moving body exists in the alarm area based on the result of the comparison, and when it is determined that the moving body exists in the alarm area, outputs an alarm signal that causes the moving body to execute processing of generating an alarm.
- (7) In the movement control system as described in (6), the prohibited section information management unit of the second traffic control device generates the prohibited section information which varies depending on a time period.
- (8) In the movement control system as described in any one of (5) to (7), the moving body is a moving body that is configured to move autonomously.
- (9) In the movement control system as described in (8), the moving body has driving modes including an autonomous driving mode for traveling autonomously along a set traveling route, and a remote driving mode for traveling based on a remote operation signal for remotely operating the moving body, and the second traffic control device further includes a mode switching signal output processing unit that, when the signal output processing unit outputs the prohibition signal, outputs a driving mode switching signal that switches the driving mode of the moving body to the remote driving mode.
- (10) A program causes a computer included in a traffic control device to execute: a positional information acquisition function that acquires positional information indicating a position of a moving body; and a signal output processing function that compares the positional information with prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section, in which the signal output processing function determines whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputs the prohibition signal.
- (11) A movement control method executed by a traffic control device includes: a positional information acquisition step of acquiring positional information indicating a position of a moving body; and a signal output processing step of comparing the positional information with prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section, in which the signal output processing step further includes determining whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputting the prohibition signal.
- (12) A moving body includes: a wireless communication unit that performs communication with the traffic control device as described in any one of (1) to (4) above; a self-position estimation unit that estimate a self-position; a driving unit; and a movement control unit that performs control of driving of the driving unit, in which the self-position estimation unit transmits estimated self-position information to the traffic control device using the wireless communication unit, and when the wireless communication unit receives a prohibition signal transmitted from the traffic control device, the movement control unit controls the driving unit to perform operation corresponding to the prohibition signal.
- (13) In the moving body as described in (12) above, the wireless communication unit receives a plurality of prohibition signals relating to restriction of movement into a same prohibited section from different traffic control devices.
- (14) In the moving body as described in (13), when the wireless communication unit receives a predetermined number of prohibition signals, the movement control unit controls the driving unit to perform operation corresponding to the prohibition signals.
- According to the present invention, it is possible to support safe movement of a moving body with a simpler configuration and processing.
-
-
FIG. 1 is a schematic diagram showing a movement control system according to an embodiment of the present invention and an example of a road to which the movement control system is applied, and is a diagram showing a state in which a moving body moves outside a prohibited section; -
FIG. 2 is a schematic diagram showing a movement control system according to an embodiment of the present invention and an example of a road to which the movement control system is applied, and is a diagram showing a state in which a moving body is located in a prohibited section; -
FIG. 3 is a block diagram showing a configuration of hardware and functional blocks of a roadside unit according to an embodiment of the present invention; -
FIG. 4A is a schematic diagram showing a positional relationship between a prohibited section and a control target area in the movement control system according to an embodiment of the present invention; -
FIG. 4B is a schematic diagram showing a positional relationship between a prohibited section and a control target area in the movement control system according to an embodiment of the present invention; -
FIG. 5 is a block diagram showing a configuration of hardware and functional blocks of a traffic control server according to an embodiment of the present invention; -
FIG. 6 is a block diagram showing a configuration of hardware and functional blocks of a moving body in the movement control system according to an embodiment of the present invention;FIG. 7 is a flowchart showing an example of movement control executed by aroadside unit 1 according to one embodiment of the present invention; -
FIG. 8 is a flowchart showing an example of movement control executed by theroadside unit 1 according to one embodiment of the present invention; -
FIG. 9 is a flowchart showing an example of movement control executed by atraffic control server 2 according to one embodiment of the present invention; -
FIG. 10 is a flowchart showing an example of movement control executed by a movingbody 3; -
FIG. 11 is a flowchart showing an example of movement control executed by the movingbody 3; -
FIG. 12 is a schematic diagram showing a movement control system according to a modification of the present invention and an example of a flight path of an unmanned flying object to which this movement control system is applied; and -
FIG. 13 is a schematic diagram illustrating a movement control system according to a modification of the present invention and an example of a road to which this movement control system is applied. - Hereinafter, a movement control system S according to an embodiment of the present invention will be described. The present invention is not limited to the following embodiments. In addition, the drawings referred to in the following description merely schematically show shapes, sizes, and positional relationships so that the contents of the present disclosure can be understood. That is, the present invention is not limited to the shapes, sizes, and positional relationships illustrated in the drawings.
- An overall configuration of a movement control system S according to one embodiment of the present invention will be described with reference to
FIG. 1. FIG. 1 is a schematic diagram illustrating an example of aroad 4 to which the movement control system S according to the present embodiment is applied. - The movement control system S is a system that controls a moving
body 3 so that the movingbody 3 does not move within a defined section on theroad 4. The movement control system S is capable of performing wireless communication with the movingbody 3, which is a vehicle traveling on theroad 4, and includes a plurality ofroadside units 1 installed on theroad 4 or on the roadside of theroad 4, and atraffic control server 2 communicably connected to each of the plurality ofroadside units 1 via a communication network NW. Each of the plurality ofroadside units 1 includes a processing unit 10 (traffic control device, first traffic control device) described later, and thetraffic control server 2 includes a processing unit 20 (traffic control device, second traffic control device) described later. That is, the movement control system S includes a plurality ofprocessing units 10 capable of performing wireless communication with the plurality ofmoving bodies 3, and aprocessing unit 20 communicably connected to the plurality ofprocessing units 10. As shown inFIG. 1 , in the present embodiment, a system for controlling autonomous driving of a vehicle will be described as an example. - The moving
body 3 is, for example, a self-driving vehicle that can move autonomously. The movingbody 3 has a driving mode including an autonomous driving mode in which the vehicle autonomously travels along a travel route set based on positional information of a destination or the like, and a remote driving mode in which the vehicle travels based on a remote operation signal for remotely operating the movingbody 3. In the autonomous driving mode, the movingbody 3 performs autonomous driving to a predetermined place based on estimated positional information of itself and map information of surroundings of where the movingbody 3 exists, which change from moment to moment. The predetermined place refers to a destination set in advance or a place on a route to the destination set in advance. The movingbody 3 is configured to be wirelessly communicable with theroadside unit 1. - The communication network NW may be a wide area network (WAN) including a private network and the Internet. In the former private network, for example, a PON access system formed by an OLT (optical line terminal), a plurality of ONUs (optical network units) connected to the OLT via an optical line, or the like, a
layer 2 switch, alayer 3 switch, or the like can be used. On the other hand, in the example of the WAN, an MPLS (Multiprotocol Label Switching) network or the like is used. - The
roadside unit 1 is also called a road side unit (RSU) or the like. The plurality ofroadside units 1 are installed in different areas around the road 4 (roadside) or the like. The area indicates a range in which eachroadside unit 1 is in charge of communication with each movingbody 3, and indicates, for example, a geographical range set along theroad 4. In the example illustrated inFIG. 1 , the plurality ofroadside units 1 are installed along theroad 4 at predetermined intervals. - The
roadside unit 1 provides a V2X (Vehicle-to-everything) communication service by performing wireless communication with the movingbody 3 traveling on theroad 4 or various devices present around theroad 4. Further, theroadside unit 1 transmits, to thetraffic control server 2 via the communication network NW, data acquired by wireless communication with the movingbody 3 traveling in an area where wireless communication is possible (hereinafter, referred to as a communicable area) and various devices in the area. Theprocessing unit 10 included in theroadside unit 1 executes movement control of the movingbody 3 by outputting various control signals to the movingbody 3. The various control signals are outputted based on the prohibited section information stored in eachroadside unit 1. The prohibited section information refers to information related to a prohibited section A indicating a predetermined section on theroad 4 as shown inFIG. 1 . Details of the prohibited section information will be described later. - The
traffic control server 2 is communicably connected to the plurality ofroadside units 1 via the communication network NW. Thetraffic control server 2 according to the present embodiment generates prohibited section information stored in each of the plurality ofroadside units 1, and manages the timing of transmitting the generated prohibited section information to theroadside units 1. The configuration of thetraffic control server 2 and the prohibited section information will be described in detail later. - Next, a functional configuration of the
roadside unit 1 in the movement control will be described.FIG. 2 is a schematic diagram illustrating the movement control system S and an example of theroad 4 to which the movement control system S is applied, and is a diagram illustrating a situation in which the movingbody 3 is located outside the prohibited section A.FIG. 3 is a block diagram illustrating a configuration of hardware and functional blocks of theroadside unit 1. - As illustrated in
FIG. 3 , theroadside unit 1 includes aprocessing unit 10, astorage unit 11, a communication I/F 12, and awireless communication unit 13. - The
processing unit 10 is an arithmetic device configured by a processor such as a CPU, reads and executes various programs and data from thestorage unit 11 described later to realize a movement control function. In the present embodiment, theprocessing unit 10 executes data processing of each functional unit of a moving bodyinformation acquisition unit 110, a prohibited sectioninformation acquisition unit 120, and a signaloutput processing unit 130. The operation of each functional unit will be described later. The operation of each functional unit will be described later. The function of the movement control of theprocessing unit 10 may be realized by hardware or may be realized by software. - The
storage unit 11 is a storage area for various programs and various data for causing the hardware group to function as theroadside unit 1, and can be configured by ROM, RAM, flash memory, a semiconductor drive (SSD), hard disk drive (HDD), or the like. Specifically, thestorage unit 11 stores a program for causing theprocessing unit 10 to execute each function of the present embodiment, a control program of theroadside unit 1, various parameters, data used for movement control of the movingbody 3, identification information such as an IP address and a MAC address of theroadside unit 1, information related to geographical map information including a communicable area, prohibited section information in the communicable area to be described later, and information indicating a position of an area to be the target of a controlled mode to be described later. - The communication I/
F 12 is an interface for theroadside unit 1 to communicate via the communication network NW. Theroadside unit 1 is communicably connected to thetraffic control server 2 via the communication I/F 12. - The
wireless communication unit 13 executes processing for theroadside unit 1 to perform V2X communication with surrounding devices wirelessly. Thewireless communication unit 13 performs wireless communication with movingbody 3 traveling in the communicable area of theroadside unit 1. Thewireless communication unit 13 receives, for example, identification information for identifying the movingbody 3, positional information indicating the position of the movingbody 3, travel information of the movingbody 3, and the like. - Next, a functional configuration for the
processing unit 10 to execute the movement control of the movingbody 3 will be described. - The moving body
information acquisition unit 110 executes processing of acquiring information relating to the movingbody 3 traveling in the communicable area of theroadside unit 1. The moving bodyinformation acquisition unit 110 includes the identificationinformation acquisition unit 111, the positionalinformation acquisition unit 112, and the travelinformation acquisition unit 113. - The identification
information acquisition unit 111 executes processing of acquiring the identification information of the movingbody 3 received via thewireless communication unit 13. The identification information acquired by the identificationinformation acquisition unit 111 may include, for example, a size of the movingbody 3, an identification ID of an on-board device mounted on the movingbody 3, a MAC address, and an IPv6 address of an on-board terminal device or the like connected to the on-board device, and number plate information. - The positional
information acquisition unit 112 executes processing of acquiring the positional information of the movingbody 3 received via thewireless communication unit 13. Examples of the positional information include latitude, longitude, and altitude of a position where the movingbody 3 exists. In the present embodiment, the positionalinformation acquisition unit 112 acquires at least latitude and longitude information as the positional information. - The travel
information acquisition unit 113 executes processing of acquiring the travel information of the movingbody 3 received via thewireless communication unit 13. The travel information includes, for example, information relating to a travel speed, a travel direction, and the like of the movingbody 3. The moving bodyinformation acquisition unit 110 associates the acquired identification information, the positional information, and the travel information of the movingbody 3 with one another, and stores them as the moving body information. - The prohibited section
information acquisition unit 120 executes processing of acquiring the prohibited section information. The prohibited section information is information indicating the position of the prohibited section A provided in the communicable area of theroadside unit 1 as shown inFIGS. 1 and2 . The prohibited section A refers to a geographical range on theroad 4 in which the movement of the movingbody 3 in the controlled mode described later in detail is prohibited. The prohibited section information is indicated by, for example, latitude, longitude, altitude, and the like. InFIGS. 1 and2 , the prohibited section A indicated by the prohibited section information of the roadside unit 1A is indicated by a broken line. In the example ofFIGS. 1 and2 , the prohibited section A of theroadside unit 1 is formed in regions on both sides of the road 4 (regions on the road side and the periphery thereof). InFIGS. 1 and2 , the prohibited section A on the lower side of the drawing shows the positional relationship of the prohibited section A on theroad 4, and the prohibited section A and the movingbody 3 on the upper side of the drawing virtually show the contents of the comparison processing of the positional information of the movingbody 3 and the prohibited section A by theprocessing unit 10 described later. - Further, the prohibited section information includes information indicating an alarm area B set around the prohibited section A. That is, the alarm area B is an area in which there is a high possibility that the moving
body 3 will move out of the prohibited section A when the movingbody 3 continues to move. In the present embodiment, the alarm area B is provided so as to surround the prohibited section A in a plan view. - The prohibited section
information acquisition unit 120 executes processing of acquiring prohibited section information from thetraffic control server 2 or thestorage unit 11. In the present embodiment, when the prohibited section information is received from thetraffic control server 2, the prohibited sectioninformation acquisition unit 120 updates the prohibited section information stored in thestorage unit 11 to the received prohibited section information. - The signal
output processing unit 130 executes processing of outputting various signals for controlling the movingbody 3 based on the positional information of the movingbody 3 and the like. The signaloutput processing unit 130 includes a mode switching signaloutput processing unit 131, a prohibition signaloutput processing unit 132, and an alarm signaloutput processing unit 133. - The mode switching signal
output processing unit 131 executes processing of outputting the first mode switching signal based on the positional information of the movingbody 3 and the prohibited section information. The first mode switching signal is a control signal including an instruction to perform mode switching for switching the mode in which the movingbody 3 moves to the controlled mode or the non-controlled mode. The controlled mode refers to a mode in which the operation of the movingbody 3 is controlled in accordance with a control signal such as a prohibition signal P or an alarm signal transmitted from theroadside unit 1. The non-controlled mode is a mode in which the operation of the movingbody 3 is not controlled by a control signal such as the prohibition signal P or the alarm signal transmitted from theroadside unit 1. - Here, a relationship between an area subject to the controlled mode (hereinafter, referred to as a control target area C) and the prohibited section A will be described.
FIGS. 4A and 4B are diagrams for explaining the relationship between the control target area C and the prohibited section A. InFIGS. 4A and 4B , the prohibited section A is indicated by a one-dot chain line, and the control target area C is indicated by a broken line. As shown inFIG. 4A , the control target area C is set to be outside the entrance and the exit of the prohibited section A in the traveling direction of the movingbody 3 on theroad 4 and to be wider than the widths of the two prohibited sections A. Further, as shown in FIG. 3B, the control target area C may be set to be at the same place as the entrance and the exit of the alarm area B existing around the prohibited section A and to be wider than the widths of the two prohibited sections A. - For example, when it is determined that the moving
body 3 has entered the control target area C based on the positional information of the movingbody 3, the mode switching signaloutput processing unit 131 outputs a first mode switching signal for performing mode switching from the non-controlled mode to the controlled mode. In addition, when it is determined that the movingbody 3 has exited the control target area C based on the positional information of the movingbody 3, the mode switching signaloutput processing unit 131 outputs the first mode switching signal for executing mode switching from the controlled mode to the non-controlled mode. - The prohibition signal
output processing unit 132 executes processing of outputting the prohibition signal P for prohibiting the movement of the movingbody 3 in the controlled mode. The prohibition signaloutput processing unit 132 compares the positional information of the movingbody 3 with the prohibited section information, and outputs the prohibition signal P based on the comparison result. Specifically, the prohibition signaloutput processing unit 132 determines whether or not the movingbody 3 exists in the prohibited section A based on the comparison result between the positional information of the movingbody 3 and the prohibited section information, and outputs the prohibition signal P when it is determined that the movingbody 3 exists in the prohibited section A. For example, the prohibition signaloutput processing unit 132 may determine that the movingbody 3 exists in the prohibited section A only when the entire movingbody 3 is located in the prohibited section A by using the information relating to the size of the movingbody 3, which is the identification information. For example, the prohibition signaloutput processing unit 132 may determine that the moving body exists in the prohibited section A when at least a part of the movingbody 3 is located in the prohibited section A. Further, when the center of the vehicle body of the movingbody 3 is located in the prohibited section A, it may be determined that the movingbody 3 exists in the prohibited section A. For example, the movingbody 3 receives control for restricting the continuous travel when the prohibition signal P is received in the controlled mode, and is allowed to perform the continuous travel when the prohibition signal P is not received. - The alarm signal
output processing unit 133 executes processing of outputting an alarm signal based on the positional information of the movingbody 3 and the prohibited section information. The alarm signal refers to a control signal including an instruction to cause the movingbody 3 to perform processing of generating an alarm that alerts the operator of the movingbody 3. The alarm signaloutput processing unit 133 compares the positional information with the information indicating the alarm area B included in the prohibited section information, and determines whether or not the movingbody 3 exists in the alarm area B based on the comparison result. When it is determined that the movingbody 3 exists in the alarm area B, the alarm signaloutput processing unit 133 outputs an alarm signal indicating that the movingbody 3 exists in the alarm area B to the movingbody 3. - Next, a functional configuration of the
traffic control server 2 in the movement control will be described.FIG. 5 is a block diagram illustrating a configuration of hardware and functional blocks of thetraffic control server 2. - As illustrated in
FIG. 5 , thetraffic control server 2 includes aprocessing unit 20, astorage unit 21, and a communication I/F 22. - The
processing unit 20 is an arithmetic device configured by a processor such as a CPU, and reads and executes various programs and data from thestorage unit 21 described later to realize a function of movement control. In the present embodiment, theprocessing unit 20 executes data processing of each functional unit of a roadside unitinformation acquisition unit 210, a mapinformation management unit 220, a prohibited sectioninformation management unit 230, and a mode switching signaloutput processing unit 240. The operation of each functional unit will be described later. The function of the movement control of theprocessing unit 20 may be realized by hardware or software. - The
storage unit 21 is a storage area for various programs for causing a hardware group to function as thetraffic control server 2, various data, and the like, and can be configured by ROM, RAM, flash memory, a semiconductor drive (SSD), hardware (HDD), or the like. Specifically, thestorage unit 21 stores a program for causing theprocessing unit 20 to execute each function of the present embodiment, a control program of thetraffic control server 2, various parameters, data used for movement control of the movingbody 3, identification information such as IP addresses and MAC addresses of a plurality ofroadside units 1 communicably connected to thetraffic control server 2, geographical map information including communicable areas of the plurality ofroadside units 1, and prohibited section information in each communicable area of the plurality ofroadside units 1. - The communication I/
F 22 is an interface for thetraffic control server 2 to communicate via the communication network NW. Thetraffic control server 2 is communicably connected to the plurality ofroadside units 1 and other communication devices via the communication I/F 22. - Next, a functional configuration for the
processing unit 20 to execute the movement control of the movingbody 3 will be described. - The roadside unit information acquisition unit 210 (positional information acquisition unit) executes processing of acquiring roadside unit information transmitted from each of the plurality of
roadside units 1. Examples of the roadside unit information include moving body information acquired by each of the plurality ofroadside units 1, information relating to an event occurring on theroad 4, and information relating to an output state of various control signals by theroadside unit 1. Examples of the information relating to the event include a traffic accident, traffic congestion, a breakdown of a vehicle, traveling of an emergency vehicle, a road surface abnormality, a fire, traveling of a maintenance vehicle on theroad 4, and the like. That is, the roadside unitinformation acquisition unit 210 acquires information such as identification information, positional information, and travel information of the movingbody 3 traveling in the communicable area of eachroadside unit 1, information relating to the occurrence situation of a traffic accident on theroad 4, and the like. Examples of the information relating to the output status of the various control signals include the presence or absence of the output of the first mode switching signal, the alarm signal, the prohibition signal P, and the like. - The map
information management unit 220 generates map information based on information acquired from the outside and updates the map information as needed. The map information may be, for example, a dynamic map. The dynamic map is a combination of static information such as road surface information, lane information, and structures, and dynamic information such as traffic regulations, construction, congestion, vehicles, pedestrians, and signals, and is a three-dimensional digital map having latitude, longitude, and altitude information. The mapinformation management unit 220 updates the dynamic map as needed based on information acquired from the outside, and transmits the dynamic map to each of the plurality ofroadside units 1. The map information transmitted to eachroadside unit 1 is transmitted from theroadside unit 1 to the movingbody 3 while traveling. - The prohibited section
information management unit 230 executes processing of generating and managing prohibited section information for each of the plurality ofroadside units 1. Specifically, the prohibited sectioninformation management unit 230 generates prohibited section information for each of the plurality ofroadside units 1 based on information acquired via the communication network NW or a predetermined program stored in thestorage unit 21. Then, the prohibited sectioninformation management unit 230 transmits the generated prohibited section information to thecorresponding roadside unit 1. The prohibited sectioninformation management unit 230 may generate different prohibited section information depending on, for example, a time period. For example, the prohibited sectioninformation management unit 230 may provide the prohibited section A on the road side of theroad 4, and may set the size of the prohibited section A in a time period such as the morning or evening when children go (back) to school (hereinafter, referred to as a school time period) to be larger than other time periods. Further, for example, the prohibited sectioninformation management unit 230 may provide the prohibited section A only in the school time period. The prohibited sectioninformation management unit 230 may generate different prohibited section information based on information acquired from the outside. For example, the prohibited sectioninformation management unit 230 may change the prohibited section information based on the information relating to the event acquired from theroadside unit 1. More specifically, when acquiring the information relating to the occurrence of the traffic accident on theroad 4, the prohibited sectioninformation management unit 230 may generate the prohibited section information indicating the prohibited section A provided at and around the accident occurrence location. Further, for example, when acquiring information indicating that a maintenance vehicle is traveling on an expressway, the prohibited sectioninformation management unit 230 may generate the prohibited section information for the maintenance vehicle to move. - The mode switching signal
output processing unit 240 executes processing of outputting a second mode switching signal (operation mode switching signal). The second mode switching signal refers to a control signal including a command to execute driving mode switching for switching the driving mode of the movingbody 3 to the autonomous driving mode or the remote driving mode. The mode switching signaloutput processing unit 240 may output the second mode switching signal based on the output state of the prohibition signal P by the signaloutput processing unit 130 of theroadside unit 1, for example. Specifically, in a case where it is determined that the prohibition signal P is outputted from theroadside unit 1, the mode switching signaloutput processing unit 240 may output the second mode switching signal to execute driving mode switching for switching the driving mode of the movingbody 3 from the autonomous driving mode to the remote driving mode. In addition, when it is determined that the positional information of the movingbody 3 is outside the prohibited section A after a predetermined time elapses from the output of the prohibition signal P, the mode switching signaloutput processing unit 240 may output the second mode switching signal to execute driving mode switching for switching the driving mode of the movingbody 3 from the remote driving mode to the autonomous driving mode, for example. - Next, a functional configuration of the moving
body 3 will be described.FIG. 6 is a block diagram illustrating the configuration of hardware and functional blocks of the movingbody 3. - As illustrated in
FIG. 6 , the movingbody 3 includes theprocessing unit 30, thestorage unit 31, thewireless communication unit 32, thesensor unit 33, theGNSS unit 34, and the drivingunit 35. - The
processing unit 30 is an arithmetic device configured by a processor such as a CPU, and reads and executes various programs and data from thestorage unit 31 described later to realize a function of movement control. In the present embodiment, theprocessing unit 30 executes data processing of each functional unit of a self-position estimation unit 310, asignal acquisition unit 320, amode switching unit 330, amovement control unit 340, and analarm control unit 350. The operation of each functional unit will be described later. - The
storage unit 31 is a storage area for various programs and various data for causing a hardware group to function as the movingbody 3, and can be configured by ROM, RAM, flash memory, a semiconductor drive (SSD), hardware (HDD), or the like. Specifically, thestorage unit 31 stores a program (a control program of the moving body 3) for causing theprocessing unit 30 to execute each function of the present embodiment, various parameters, data used for movement control of the movingbody 3, identification information such as an identification ID and an IP address of the movingbody 3, map information, and the like. Examples of the map information include a dynamic map. - The
wireless communication unit 32 executes processing for the movingbody 3 to wirelessly communicate with theroadside unit 1. Thewireless communication unit 32 transmits, for example, identification information for identifying the movingbody 3, positional information indicating the position of the movingbody 3, travel information of the movingbody 3, and the like to theroadside unit 1, and receives various control signals such as the first mode switching signal, the prohibition signal P, and the alarm signal, the map information generated by thetraffic control server 2, and the like from theroadside unit 1. Thewireless communication unit 32 communicates with theprocessing unit 10 via thewireless communication unit 13 of theroadside unit 1. - The
sensor unit 33 is a device for detecting information relating to the surroundings of the movingbody 3 itself. Thesensor unit 33 may be, for example, radar or LIDAR (light detection and ranging) that detects a distance, a direction, a relative speed, or the like relative to an object present around the movingbody 3 based on a transmission wave transmitted to the periphery of the movingbody 3 and a reflected received wave, or may be a camera or the like. In the present embodiment, as thesensor unit 33, LIDAR is used which irradiates laser light around the movingbody 3 and detects a surrounding object as point cloud data. According to LIDAR, it is possible to detect the position, the shape, and the like of the surrounding object with high accuracy. Thesensor unit 33 transmits the detected point cloud data to theprocessing unit 30. - The GNSS (Global Navigation Satellite System)
unit 34 includes an antenna and receives a GNSS signal and the like. The GNSS signal is transmitted from a navigation satellite or the like that make up a GNSS such as GPS (Global Positioning System) or a quasi-zenith satellite system. TheGNSS unit 34 transmits the received GNSS signal to theprocessing unit 30. - The driving
unit 35 is a part related to driving of the movingbody 3, such as an engine, a motor, or a brake. - Next, a functional configuration for the
processing unit 30 to execute movement control of the movingbody 3 will be described. - The self-
position estimation unit 310 executes processing of estimating positional information indicating the position of the movingbody 3 itself. For example, the self-position estimation unit 310 may estimate the positional information of the movingbody 3 based on the map information received from thetraffic control server 2, the point cloud data around the movingbody 3 received from thesensor unit 33, the GNSS signal received from theGNSS unit 34, and the like. More specifically, the self-position estimation unit 310 may estimate the positional information of the movingbody 3 by collating the map information with the point cloud data around the movingbody 3. The positional information estimated by the self-position estimation unit 310 is transmitted to theroadside unit 1 via thewireless communication unit 32. - The
signal acquisition unit 320 executes processing of acquiring various control signals such as the first mode switching signal, the second mode switching signal, the prohibition signal P, and the alarm signal from theroadside unit 1 via thewireless communication unit 32. - When the first mode switching signal is acquired by the
signal acquisition unit 320, themode switching unit 330 switches the movement mode of the movingbody 3. Specifically, when the first mode switching signal for executing mode switching from the non-controlled mode to the controlled mode is acquired in a state where the movement mode of the movingbody 3 is the non-controlled mode, themode switching unit 330 switches the movement mode to the controlled mode. On the other hand, when the first mode switching signal for performing mode switching from the controlled mode to the non-controlled mode is acquired in a state where the movement mode of the movingbody 3 is the controlled mode, themode switching unit 330 switches the movement mode from the controlled mode to the non-controlled mode. - When the second mode switching signal is acquired by the
signal acquisition unit 320, themode switching unit 330 switches the operation mode of the movingbody 3. Specifically, when the second mode switching signal is acquired in a state where the driving mode of the movingbody 3 is the autonomous driving mode, themode switching unit 330 switches the driving mode to the remote driving mode. Conversely, when the second mode switching signal is acquired in a state where the driving mode of the movingbody 3 is the remote driving mode, themode switching unit 330 switches the driving mode from the remote driving mode to the autonomous driving mode. - When the driving mode of the moving
body 3 is the autonomous driving mode, themovement control unit 340 executes processing of controlling the movement of the movingbody 3 based on the positional information, etc. estimated by the self-position estimation unit 310. Specifically, themovement control unit 340 controls the movement to the set destination by controlling the driving of the drivingunit 35 based on the positional information and the travel information of the movingbody 3, the map information stored in thestorage unit 31, and the like. - When the driving mode of the moving
body 3 is the remote driving mode, themovement control unit 340 stops the autonomous driving and executes processing of controlling the movement of the movingbody 3 based on the remote operation signal. For example, the remote control signal may be transmitted to the movingbody 3 via the communication network NW from a facility such as a traffic control center having, for example, thetraffic control server 2. The remote control signal may be generated as a signal such that the movingbody 3 moves to the outside of the prohibited section A based on, for example, the positional information of the movingbody 3 or the map information acquired via thetraffic control server 2, the prohibited section information, the image captured by the movingbody 3 or theroadside unit 1, or the like. - When the movement mode of the moving
body 3 is the controlled mode, themovement control unit 340 executes processing of controlling the driving of the movingbody 3 based on the acquisition status of the prohibition signal P by thesignal acquisition unit 320. When the prohibition signal P transmitted from theprocessing unit 10 of theroadside unit 1 is received by thewireless communication unit 32, themovement control unit 340 controls the drivingunit 35 to perform an operation corresponding to the prohibition signal P. The operation corresponding to the prohibition signal P refers to, for example, an operation of stopping the driving of the movingbody 3 or an operation for the movingbody 3 to leave from the prohibited section A. When the prohibition signal P is acquired by thesignal acquisition unit 320, themovement control unit 340 may execute control for stopping the movingbody 3, and may control the movingbody 3 so that the movingbody 3 in the prohibited section A leaves the prohibited section A. The control for stopping the movingbody 3 may be, for example, control for stopping the movingbody 3 after decelerating to a predetermined speed. In addition, for example, when the prohibition signal P is acquired a predetermined number of times or more within the determination period, themovement control unit 340 may execute control for stopping the movingbody 3 or control for leaving the prohibited section A. - When the movement mode of the moving
body 3 is the controlled mode and the alarm signal is acquired by thesignal acquisition unit 320, thealarm control unit 350 executes processing for generating an alarm. The alarm may be audio information, textual information, or the like to inform the operator of the movingbody 3 of the possibility of entering the prohibited section A. For example, thealarm control unit 350 may display an alarm on a liquid crystal display or a mirror disposed in the movingbody 3 or may generate audio information from a speaker disposed in the movingbody 3. - Next, an example of movement control on the
road 4 by the movement control system S will be described with reference toFIGS. 1 and2 . - In the situation shown in
FIG. 1 , the movingbody 3 is traveling between two prohibited sections A on theroad 4. As shown inFIG. 1 , in the comparison result by the prohibition signaloutput processing unit 132 of theroadside unit 1, the movingbody 3 is located outside the prohibited section A, and thus the prohibition signal P is not outputted. Therefore, the movingbody 3 is continuously running. - On the other hand, in a case of the situation shown in
FIG. 2 , in the comparison result by the prohibition signaloutput processing unit 132 of theroadside unit 1, the movingbody 3 is located in the prohibited section A, and thus the prohibition signal P is transmitted to the movingbody 3. As a result, the movingbody 3 decelerates and stops as shown inFIG. 2 , for example. - Next, a flow of the movement control of the moving
body 3 by the movement control system S according to the present embodiment will be described. It is to be noted that the contents of the processing in the following operation description are merely examples, and various types of processing capable of obtaining similar results can be adopted as appropriate. - First, the flow of processing of the movement control executed by the
roadside unit 1 will be described with reference toFIGS. 7 and8 .FIG. 7 is a flowchart showing an example of processing up to the output of the first mode switching signal in the movement control executed by theprocessing unit 10 of theroadside unit 1, andFIG. 8 is a flowchart showing an example of processing for controlling the movingbody 3 in the controlled mode. Theprocessing unit 10 executes the processing ofFIGS. 7 and8 based on, for example, a program stored in thestorage unit 11 or the like. The flows of the processing exemplified inFIGS. 7 and8 each start the processing when the installedroadside unit 1 is activated, and then continue the processing during the operation of theroadside unit 1. - As illustrated in
FIG. 7 , in step S11, the positionalinformation acquisition unit 112 acquires the positional information of the movingbody 3 received via thewireless communication unit 13. - In step S12, the mode switching signal
output processing unit 131 compares the positional information acquired in step S11 with the information indicating the position of the control target area C stored in thestorage unit 11, and determines whether the movingbody 3 has entered the control target area C. When it is determined that the movingbody 3 has entered the control target area C (step S12; YES), the mode switching signaloutput processing unit 131 proceeds to step S13. On the other hand, when it is determined that the movingbody 3 is located outside the control target area C (step S12; NO), the mode switching signaloutput processing unit 131 repeats the processing of step S11. - In step S13, the mode switching signal
output processing unit 131 outputs the first mode switching signal for switching the movingbody 3 to the controlled mode. Then, the first mode switching signal is transmitted to the movingbody 3 by thewireless communication unit 13. - As illustrated in
FIG. 8 , in step S21, the prohibited sectioninformation acquisition unit 120 extracts the prohibited section information from thestorage unit 11. - In step S22, the positional
information acquisition unit 112 acquires the positional information of the movingbody 3 received via thewireless communication unit 13. - In step S23, the prohibition signal
output processing unit 132 compares the prohibited section information acquired in step S21 with the positional information acquired in step S22, and determines whether or not the movingbody 3 is located within the prohibited section A. When the prohibition signaloutput processing unit 132 determines that the movingbody 3 is located within the prohibited section A (step S23; YES), the processing proceeds to step S24. On the other hand, when the prohibition signaloutput processing unit 132 determines that the movingbody 3 is located outside the prohibited section A (step S23; NO), the processing of step S22 is repeated. - In step S24, the prohibition signal
output processing unit 132 outputs the prohibition signal P for prohibiting the movement of the movingbody 3 in the prohibited section A. Then, the prohibition signal P is transmitted to the movingbody 3 by thewireless communication unit 13. Thereafter, theprocessing unit 10 returns the processing to step S22. - Next, a flow of processing of the movement control executed by the
traffic control server 2 will be described with reference toFIG. 9. FIG. 9 is a flowchart illustrating an example of processing of the movement control executed by theprocessing unit 20 of thetraffic control server 2. Theprocessing unit 20 executes the processing ofFIG. 9 based on, for example, a program stored in thestorage unit 21 or the like. The flow of processing illustrated inFIG. 9 starts the processing when thetraffic control server 2 installed is activated, and then continues the processing while thetraffic control server 2 is operating. - As illustrated in
FIG. 9 , in step S31, the roadside unitinformation acquisition unit 210 acquires roadside unit information that is transmitted from each of the plurality ofroadside units 1, and includes the output status of the prohibition signal P by each of theroadside units 1 and the positional information of the movingbody 3. - In step S32, the mode switching signal
output processing unit 240 determines whether or not the prohibition signal P is outputted by theroadside unit 1 based on the roadside unit information acquired in step S31. When it is determined that the prohibition signal P is outputted by the roadside unit 1 (step S32; YES), the mode switching signaloutput processing unit 240 causes the processing to proceed to step S33. On the other hand, when it is determined that the prohibition signal P is not outputted by the roadside unit 1 (step S32; NO), the mode switching signaloutput processing unit 240 returns the processing to step S31. - In step S33, the mode switching signal
output processing unit 240 outputs the second mode switching signal. Then, the second mode switching signal is transmitted to the movingbody 3 via theroadside unit 1 and thewireless communication unit 13 which outputted the prohibition signal P. - Next, a flow of processing of the movement control executed by the moving
body 3 will be described with reference toFIGS. 10 and11 .FIG. 10 is a flowchart showing an example of processing executed by the movingbody 3 until the movement mode is switched to the controlled mode, andFIG. 11 is a flowchart showing an example of processing executed by the movingbody 3 in the controlled mode. It is to be noted that the movingbody 3 at the start of the flow ofFIG. 10 assumes that the movement mode is the non-controlled mode and the driving mode is the autonomous driving mode. - As illustrated in
FIG. 10 , in step S41, the self-position estimation unit 310 estimates the positional information indicating the position of the movingbody 3 itself. The self-position estimation unit 310 estimates the positional information of the movingbody 3 itself based on, for example, the map information received from thetraffic control server 2 via theroadside unit 1 and point cloud data received from thesensor unit 33. - In step S42, the
wireless communication unit 32 transmits the positional information of the movingbody 3 estimated in step S41 to theroadside unit 1. - In step S43, the
mode switching unit 330 determines whether or not the first mode switching signal has been received from theroadside unit 1. When it is determined that the first mode switching signal has been acquired by the signal acquisition unit 320 (step S43; YES), themode switching unit 330 causes the processing to proceed to step S44. On the other hand, when it is determined that thesignal acquisition unit 320 has not acquired the first mode switching signal (step S43; NO), themode switching unit 330 returns the processing to step S31. - In step S44, the
mode switching unit 330 switches the movement mode of the movingbody 3 to the controlled mode. - As illustrated in
FIG. 11 , in step S51, the self-position estimation unit 310 estimates the positional information indicating the position of the movingbody 3 itself. The self-position estimation unit 310 estimates the positional information of the movingbody 3 itself based on, for example, the map information received from thetraffic control server 2 via theroadside unit 1 and point cloud data received from thesensor unit 33. - In step S52, the
wireless communication unit 32 transmits the positional information of the movingbody 3 estimated in step S51 to theroadside unit 1. - In step S53, the
movement control unit 340 determines whether or not thesignal acquisition unit 320 has received the prohibition signal P. When it is determined that the prohibition signal P is acquired by the signal acquisition unit 320 (step S53; YES), themovement control unit 340 causes the processing to proceed to step S54. On the other hand, when it is determined that thesignal acquisition unit 320 has not acquired the prohibition signal P (step S53; NO), themovement control unit 340 returns the processing to step S51. - In step S54, the
movement control unit 340 controls the drivingunit 35 to stop the movement of the movingbody 3. - In step S55, the
processing unit 30 receives the second mode switching signal from thetraffic control server 2. Then, themode switching unit 330 switches the driving mode of the movingbody 3 from the autonomous driving mode to the remote driving mode. - According to the embodiment described above, the following advantageous effects are obtained.
- The
processing unit 10 according to the present embodiment includes the positionalinformation acquisition unit 112 that acquires positional information indicating the position of the movingbody 3, and the signaloutput processing unit 130 that compares the positional information with the prohibited section information indicating the prohibited section A in which the movement of the movingbody 3 is prohibited, and outputs the prohibition signal P that prohibits the movement of the movingbody 3 in the prohibited section A based on the result of the comparison. The signaloutput processing unit 130 determines whether the movingbody 3 exists in the prohibited section A based on the result of the comparison, and when it is determined that the movingbody 3 exists in the prohibited section A, outputs the prohibition signal P. With such a configuration, it is possible to move the movingbody 3 in a determined area by the simple processing of comparing the position of the movingbody 3 with the prohibited section A. For example, by providing the prohibited section A in an area including the oncoming lane, the road side, and the sidewalk of the road 7, it is possible to prevent the movingbody 3 from entering the area and causing an accident if an abnormality occurs in the control of the self-driving vehicle or if an elderly driver erroneously performs a driving operation. Therefore, it is possible to assist in the safe movement of the movingbody 3 with a simple configuration and processing. - In addition, in the
processing unit 10 according to the present embodiment, the prohibited section information includes information indicating the alarm area B set around the prohibited section A, and the signaloutput processing unit 130 determines whether the movingbody 3 exists in the alarm area B based on a result of the comparison, and when it is determined that the movingbody 3 exists in the alarm area B, outputs an alarm signal for causing the movingbody 3 to execute the processing whereby the movingbody 3 generates an alarm. With such a configuration, since an alarm is generated when the movingbody 3 approaches the prohibited section A, the operator or the like of the movingbody 3 can grasp the possibility of entry of the movingbody 3 into the prohibited section A. Therefore, it is easy to avoid entry of the movingbody 3 into the prohibited section A. - Further, in the
processing unit 10 according to the present embodiment, the movingbody 3 is the movingbody 3 which is configured to move autonomously. With such a configuration, even if an abnormality occurs in the traveling of the self-driving vehicle, it is possible to suppress the traveling of the self-driving vehicle in the prohibited section A. - The
roadside unit 1 according to the present embodiment is theroadside unit 1 which includes each constituent element of theprocessing unit 10, and is installed on theroad 4 on which the movingbody 3 moves or at the roadside of theroad 4. With such a configuration, it is possible to assist in the safe movement of the movingbody 3 traveling on theroad 4 by a simple configuration and processing. - The movement control system S according to the present embodiment is configured to be able to perform wireless communication with the moving
body 3, and includes the plurality ofroadside units 1 each installed in a different area, and thetraffic control server 2 communicably connected to the plurality ofroadside units 1. Thetraffic control server 2 includes the prohibited sectioninformation management unit 230 that generates the prohibited section information indicating the prohibited section A in which the movement of the movingbody 3 is prohibited and transmits the prohibited section information to each of the plurality ofroadside units 1. Theroadside unit 1 includes the positionalinformation acquisition unit 112 that acquires positional information indicating the position of the movingbody 3 and the signaloutput processing unit 130 that compares the positional information with the prohibited section information received from thetraffic control server 2 and outputs the prohibition signal P that prohibits the movement of the movingbody 3 in the prohibited section A based on a result of the comparison. The signaloutput processing unit 130 determines whether the movingbody 3 exists in the prohibited section A based on the result of the comparison, and when it is determined that the movingbody 3 exists in the prohibited section A, outputs the prohibition signal P. With such a configuration, it is possible to prevent the movingbody 3 from moving in an area where there is a risk of danger, by simple processing of comparing the position of the movingbody 3 with the prohibited section A. For example, by providing the prohibited section A in an area including the oncoming lane, the road side, and the sidewalk of the road 7, it is possible to prevent the movingbody 3 from entering the area and causing an accident if an abnormality occurs in the control of the self-driving vehicle or if an elderly driver erroneously performs a driving operation. Therefore, it is possible to assist in the safe movement of the movingbody 3 with a simple configuration and processing. - In addition, in the movement control system S according to the present embodiment, the prohibited section information includes information indicating the alarm area B set around the prohibited section A, and the signal
output processing unit 130 of theroadside unit 1 determines whether the movingbody 3 exists in the alarm area B based on the result of the comparison, and when it is determined that the movingbody 3 exists in the alarm area B, outputs an alarm signal for causing the movingbody 3 to perform processing of generating an alarm. With such a configuration, since an alarm is generated when the movingbody 3 approaches the prohibited section A, the operator or the like of the movingbody 3 can grasp the possibility of entry of the movingbody 3 into the prohibited section A. Therefore, it is easy to avoid entry of the movingbody 3 into the prohibited section A. - In addition, in the movement control system S according to the present embodiment, the prohibited section
information management unit 230 of thetraffic control server 2 generates the prohibited section information which varies depending on a time period. With such a configuration, since the position, size, and the like of the prohibited section A can be changed in consideration of traffic conditions and the like that vary according to the time period, it is possible to move the movingbody 3 more safely. - In the movement control system S according to the present embodiment, the moving
body 3 is a movingbody 3 that is configured to move autonomously. With such a configuration, even if an abnormality occurs in the traveling of the self-driving vehicle, it is possible to suppress the traveling of the self-driving vehicle in the prohibited section A. - Further, in the movement control system S according to the present embodiment, the moving
body 3 has driving modes including the autonomous driving mode in which the vehicle autonomously travels along a set travel route and the remote driving mode in which the vehicle travels based on a remote operation signal for remotely operating the movingbody 3. Thetraffic control server 2 further includes the mode switching signaloutput processing unit 240 that outputs a driving mode switching signal for switching the driving mode of the movingbody 3 to the remote driving mode when the prohibition signal P is outputted by the signaloutput processing unit 130. With such a configuration, even when the movingbody 3 enters the prohibited section A, it is possible to return the movingbody 3 to outside of the prohibited section A by, for example, remote control, and it is possible to continue the safe movement of the movingbody 3. Therefore, it is possible to move the movingbody 3 safely without interfering with the movement of another movingbody 3. - The program according to the present embodiment causes a computer included in the
roadside unit 1 to execute: a positional information acquisition function of acquiring positional information indicating a position of the movingbody 3; and a signal output processing function of comparing the positional information with prohibited section information indicating the prohibited section A in which the movement of movingbody 3 is prohibited, and outputting the prohibition signal P for prohibiting the movement of movingbody 3 in the prohibited section A based on a result of the comparison. The signal output processing function determines whether the movingbody 3 exists in the prohibited section A based on the result of the comparison and, when it is determined that the movingbody 3 exists in the prohibited section A, outputs the prohibition signal P. With such a configuration, it is possible to prevent the movingbody 3 from moving in an area where there is a risk of danger by simple processing of comparing the position of the movingbody 3 with the prohibited section A. For example, by providing the prohibited section A in an area including the oncoming lane, the road side, and the sidewalk of the road 7, it is possible to prevent the movingbody 3 from entering the area and causing an accident if an abnormality occurs in the control of the self-driving vehicle or if the elderly driver erroneously performs the driving operation. Therefore, it is possible to assist the safe movement of the movingbody 3 with a simple configuration and processing. - A movement control method according to the present embodiment is a movement control method executed by a
roadside unit 1, and the method includes: a positional information acquisition step of acquiring positional information indicating a position of the movingbody 3; and a signal output processing step of comparing the positional information with prohibited section information indicating the prohibited section A in which the movement of movingbody 3 is prohibited, and outputting the prohibition signal P for prohibiting the movement of the movingbody 3 based on a result of the comparison. The signal output processing step determines whether the movingbody 3 exists in the prohibited section A based on the result of the comparison, and when it is determined that the movingbody 3 exists in the prohibited section A, the signal output processing step outputs the prohibition signal P. With such a configuration, it is possible to prevent the movingbody 3 from moving in an area where there is a risk of danger by simple processing of comparing the position of the movingbody 3 with the prohibited section A. For example, by providing the prohibited section A in an area including the oncoming lane, the road side, and the sidewalk of the road 7, it is possible to prevent the movingbody 3 from entering the area and causing an accident if an abnormality occurs in the control of the self-driving vehicle or if an elderly driver erroneously performs a driving operation. Therefore, it is possible to assist in the safe movement of the movingbody 3 with a simple configuration and processing. - The moving
body 3 according to the present embodiment includes thewireless communication unit 32 that communicates with theprocessing unit 10, the self-position estimation unit 310 that estimates a self-position, the drivingunit 35, and themovement control unit 340 that controls driving of the drivingunit 35. The self-position estimation unit 310 transmits the estimated self-positional information to theprocessing unit 10 using thewireless communication unit 32. Themovement control unit 340 controls the drivingunit 35 to perform operation corresponding to the prohibition signal P when themovement control unit 340 receives the prohibition signal P transmitted from theprocessing unit 10 using thewireless communication unit 32. With such a configuration, it is possible to provide the movingbody 3 which is managed and controlled by theroadside unit 1 including theprocessing unit 10. Therefore, it is possible to assist in the safe movement of the movingbody 3 with a simple configuration and processing. - Although embodiments of the present invention have been described above, the present invention is not limited to the above-described embodiments, and can be appropriately modified.
- Although the moving
body 3 in the above embodiment is a self-driving vehicle, it may be a vehicle that does not have an autonomous driving function. Further, the vehicle may be a four-wheeled motor vehicle or a two-wheeled motor vehicle. Also, the movingbody 3 is not limited to vehicles and may be an unmanned flying object, such as a drone. In particular, in a case of an unmanned flying object, 3D map information made mainly using latitude, longitude, and altitude information is used. - Here, the configuration of a movement control system S in a case in which the moving
body 3 is an unmanned flying object will be described.FIG. 12 is a schematic diagram illustrating an example of a flight path of an unmanned flying object to which the movement control system S according to a modification of the present embodiment is applied. - The unmanned flying object is used for checking the state of
electric wires 51 suspended by asteel tower 50, checking the state of a road or a wall surface in a tunnel, checking the state of a structure bridging over a river, a canal, a railway line, a road, or the like, checking a building, monitoring a river, a cliff, or a sea, and the like during a disaster. In the example shown inFIG. 12 , the state of theelectric wires 51 of thesteel tower 50 is inspected using an autonomously movable unmanned flying object. - The prohibited section A in which the unmanned flying object can fly is defined by latitude, longitude, and altitude. In addition, in the example illustrated in
FIG. 12 , the shape of the prohibited section A is a prismatic shape, but is not limited to this shape, and various shapes such as a cylindrical shape can be considered. In the example shown inFIG. 12 , the prohibited section A is set so as to surround thesteel tower 50 and theelectric wires 51. - In the example illustrated in
FIG. 12 ,roadside units roadside units steel tower 50 may be performed. This makes it possible to prevent the unmanned flying object from coming into contact with thesteel tower 50 and theelectric wires 51 during inspection of theelectric wires 51. - The moving
body 3 may also be a working robot. In this case, a prohibited section as an entry prohibited section may be set using 3D map information including information of latitude, longitude, and altitude. With such a configuration, for example, when the working robot enters the prohibited section, it is possible to perform safety assist to stop the operation of the robot. Further, the movingbody 3 can set a V2X communication terminal of a pedestrian or worker, also called V2P (Vehicle-to-Pedestrian) as its target. In this case, for example, when the worker enters the prohibited section set as a dangerous area, an alarm can be issued to the worker from the V2X communication terminal. - In the above embodiment, each of the
roadside units 1 includes the signaloutput processing unit 130, but thetraffic control server 2 may acquire the positional information of the movingbody 3 via each of theroadside units 1, and output the first mode switching signal, the prohibition signal P, and the alarm signal based on the comparison between the positional information and the prohibited section information. - In the above embodiment, the
traffic control server 2 outputs the second mode switching signal for switching the operation mode of the movingbody 3, but each of theroadside units 1 may output the mode switching signal for switching the operation mode of the movingbody 3 between the autonomous driving mode and the remote driving mode. - The movement control system S is not limited to the above-described configuration, and may have another configuration.
FIG. 13 is a schematic diagram illustrating a movement control system S according to a modification of the present embodiment and an example of aroad 4 to which the movement control system S is applied. The movement control system S includes a plurality ofroadside units 1 includingroadside units road 4, or around or in the vicinity of theroad 4 such as at the roadside of theroad 4, and are capable of performing wireless communication with the movingbody 3, which is a vehicle traveling on theroad 4, and atraffic control server 2 communicably connected to each of the plurality ofroadside units 1 via a communication network NW. Theroadside units 1G and theroadside units 1H have the same configuration. The plurality ofroadside units 1G are disposed at predetermined intervals along theroad 4. Each of theroadside units 1H is disposed at a position opposite to a corresponding one of theroadside unit 1G across theroad 4. Further, the plurality ofroadside units 1G and the plurality ofroadside units 1H may be disposed along theroad 4 so as to cover the entire length of the prohibited section A, or one or a plurality ofroadside units road 4 only at a specific place. The specific place refers to, for example, any place designated by the operator, such as a construction site. In the above description, the prohibited section A of each of the plurality ofroadside units 1 is set in such a manner that the entire prohibited sections A are overlapped with each other, but the present invention is not limited thereto, and the prohibited section A of each of the plurality ofroadside units 1 is set in such a manner that the prohibited sections A are partially overlapped with each other. With such a configuration, when the movingbody 3 is located in the overlapping prohibited sections A, the movingbody 3 receives a plurality of prohibition signals P. - The
wireless communication unit 32 of the movingbody 3 receives a plurality of prohibition signals P relating to movement into the same prohibited section A fromdifferent roadside units 1. In the example illustrated inFIG. 13 , the movingbody 3 transmits the positional information to each of theroadside units 1G and theroadside units 1H. Theroadside unit 1G transmits the positional information received from the movingbody 3 to thetraffic control server 2. Further, theroadside unit 1H transmits the positional information received from the movingbody 3 to thetraffic control server 2. - The
traffic control server 2 generates a prohibition signal PG if the movingbody 3 exists in the prohibited section A based on the positional information received from theroadside unit 1G, and transmits the generated prohibition signal PG to theroadside unit 1G. Then, theroadside unit 1G transmits the prohibition signal PG to the movingbody 3. In addition, thetraffic control server 2 generates a prohibition signal PH if the movingbody 3 exists in the prohibited section A based on the positional information received from theroadside unit 1H, and transmits the generated prohibition signal PH to theroadside unit 1H. Then, theroadside unit 1H transmits the prohibition signal PH to the movingbody 3. - The
wireless communication unit 32 of the movingbody 3 receives the plurality of prohibition signals P related to restriction of movement into the same prohibited section A fromdifferent processing units 10. In the example illustrated inFIG. 13 , thewireless communication unit 32 receives, from theroadside unit 1G and theroadside unit 1H, the prohibition signals P related to restriction of movement into the same prohibited section A. The prohibition signal P may be generated by theroadside unit 1. In this configuration, thetraffic control server 2 transmits, to eachroadside unit 1 at a predetermined timing, information of the latest prohibited section A adapted to the place where eachroadside unit 1 is disposed. Based on the positional information received from the movingbody 3, theroadside unit 1G and theroadside unit 1H each generate the prohibition signal P if the movingbody 3 exists in the prohibited section A, and transmit the generated prohibition signal P to the movingbody 3. - When the
wireless communication unit 32 receives a predetermined number of prohibition signals P, themovement control unit 340 of the movingbody 3 may control the drivingunit 35 to perform operation corresponding to the prohibition signals P. Specifically, when the predetermined number is "1", themovement control unit 340 of the movingbody 3 controls the drivingunit 35 to be driven when the prohibition signal PG or the prohibition signal PH is received. When the predetermined number is "2", themovement control unit 340 of the movingbody 3 may control the drivingunit 35 to be driven when the prohibition signal PG and the prohibition signal PH are received. In this way, with such a configuration in which each of theroadside units 1 is disposed at a position opposite to a corresponding one of theroadside unit 1 across theroad 4, even when, for example, the movingbody 3 runs in parallel with a large-sized moving body (for example, a truck or the like), it is possible for the movement control system S to reliably acquire the positional information of the movingbody 3, which is the target, by theroadside unit 1 disposed on one side, and achieve a blind spot countermeasure. In addition, since the plurality ofroadside units 1 are disposed at different positions with respect to the same prohibited section A, even when any one of theroadside units 1 fails, it is still possible for the movement control system S to reliably acquire the positional information of thetarget moving body 3 by anotherroadside unit 1, and achieve a countermeasure against the failure of the device. -
- 1 Roadside unit
- 2 Traffic control server
- 3 Moving body
- 10 Processing unit (traffic control device, first traffic control device)
- 20 Processing unit (traffic control device, second traffic control device)
- 32 Wireless communication unit
- 35 Driving unit
- 112 Positional information acquisition unit
- 130 Signal output processing unit
- 230 Prohibited section information management unit
- 310 Self-position estimation unit
- 340 Movement control unit
- A Prohibited section
- P Prohibition signal
- S Movement control system
Claims (14)
- A traffic control device comprising:a positional information acquisition unit that acquires positional information indicating a position of a moving body; anda signal output processing unit that compares the positional information with prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section,wherein the signal output processing unit determines whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputs the prohibition signal.
- The traffic control device according to claim 1, whereinthe prohibited section information includes information indicating an alarm area set around the prohibited section, andthe signal output processing unit determines whether the moving body exists in the alarm area based on the result of the comparison, and when it is determined that the moving body exists in the alarm area, outputs an alarm signal that causes the moving body to execute processing of generating an alarm.
- The traffic control device according to claim 1, wherein the moving body is a moving body that is configured to move autonomously.
- A roadside unit comprising each component of the traffic control device according to any one of claims 1 to 3, the roadside unit being installed on a road on which the moving body moves or on a roadside of the road.
- A movement control system that is configured to wirelessly communicate with a moving body, the movement control system comprising:a plurality of first traffic control devices each installed in a different area; anda second traffic control device that is communicably connected to the plurality of first traffic control devices,wherein the second traffic control device includes a prohibited section information management unit that generates prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and transmits the prohibited section information to each of the plurality of first traffic control devices,the first traffic control device includes:a positional information acquisition unit that acquires positional information indicating a position of the moving body, anda signal output processing unit that compares the positional information with the prohibited section information received from the second traffic control device, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section, andthe signal output processing unit determines whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputs the prohibition signal.
- The movement control system according to claim 5, whereinthe prohibited section information includes information indicating an alarm area set around the prohibited section, andthe signal output processing unit of the first traffic control device determines whether the moving body exists in the alarm area based on the result of the comparison, and when it is determined that the moving body exists in the alarm area, outputs an alarm signal that causes the moving body to execute processing of generating an alarm.
- The movement control system according to claim 6, wherein the prohibited section information management unit of the second traffic control device generates the prohibited section information which varies depending on a time period.
- The movement control system according to any one of claims 5 to 7, wherein the moving body is a moving body that is configured to move autonomously.
- The movement control system according to claim 8, whereinthe moving body has driving modes including an autonomous driving mode for traveling autonomously along a set traveling route, and a remote driving mode for traveling based on a remote operation signal for remotely operating the moving body, andthe second traffic control device further includes a mode switching signal output processing unit that, when the signal output processing unit outputs the prohibition signal, outputs a driving mode switching signal that switches the driving mode of the moving body to the remote driving mode.
- A program that causes a computer included in a traffic control device to execute:a positional information acquisition function that acquires positional information indicating a position of a moving body; anda signal output processing function that compares the positional information with prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section,wherein the signal output processing function determines whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputs the prohibition signal.
- A movement control method executed by a traffic control device, the method comprising:a positional information acquisition step of acquiring positional information indicating a position of a moving body; anda signal output processing step of comparing the positional information with prohibited section information indicating a prohibited section in which a movement of the moving body is prohibited, and outputs, based on a result of the comparison, a prohibition signal that prohibits the movement of the moving body in the prohibited section,wherein the signal output processing step further includes determining whether the moving body exists in the prohibited section based on the result of the comparison, and when it is determined that the moving body exists in the prohibited section, outputting the prohibition signal.
- A moving body comprising:a wireless communication unit that performs communication with the traffic control device according to claim 1;a self-position estimation unit that estimates a self-position;a driving unit; anda movement control unit that performs control of driving of the driving unit,wherein the self-position estimation unit transmits estimated self-position information to the traffic control device using the wireless communication unit, andwhen the wireless communication unit receives a prohibition signal transmitted from the traffic control device, the movement control unit controls the driving unit to perform operation corresponding to the prohibition signal.
- The moving body according to claim 12, wherein the wireless communication unit receives a plurality of prohibition signals relating to restriction of movement into a same prohibited section from different traffic control devices.
- The moving body according to claim 13, wherein, when the wireless communication unit receives a predetermined number of prohibition signals, the movement control unit controls the driving unit to perform operation corresponding to the prohibition signals.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2022094268A JP2023180726A (en) | 2022-06-10 | 2022-06-10 | Control device, roadside machine, movement control system, program, movement control method, and mobile object |
| PCT/JP2023/016290 WO2023238539A1 (en) | 2022-06-10 | 2023-04-25 | Coordination device, roadside unit, movement control system, program, movement control method, and moving body |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP4535331A1 true EP4535331A1 (en) | 2025-04-09 |
| EP4535331A4 EP4535331A4 (en) | 2025-10-15 |
Family
ID=89118081
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP23819526.7A Pending EP4535331A4 (en) | 2022-06-10 | 2023-04-25 | COORDINATION DEVICE, ROADSIDE UNIT, MOTION CONTROL SYSTEM, PROGRAM, MOTION CONTROL METHOD, AND MOVING BODY |
Country Status (3)
| Country | Link |
|---|---|
| EP (1) | EP4535331A4 (en) |
| JP (1) | JP2023180726A (en) |
| WO (1) | WO2023238539A1 (en) |
Family Cites Families (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP3941312B2 (en) * | 1999-12-24 | 2007-07-04 | 株式会社日立製作所 | Road traffic system and information processing method thereof |
| JP6443160B2 (en) * | 2015-03-23 | 2018-12-26 | 株式会社デンソー | Automatic travel control device or automatic travel control system |
| US10162059B2 (en) * | 2015-03-30 | 2018-12-25 | International Business Machines Corporation | Implementing a restricted-operation region for unmanned vehicles |
| JP6229905B2 (en) * | 2016-03-28 | 2017-11-15 | パナソニックIpマネジメント株式会社 | Reverse run prevention system |
| JP6759149B2 (en) * | 2017-04-26 | 2020-09-23 | 京セラ株式会社 | Roadside machine, vehicle, roadside machine control method and control program |
| US11176831B2 (en) * | 2018-06-15 | 2021-11-16 | Phantom Auto Inc. | Restricting areas available to autonomous and teleoperated vehicles |
| JP2020140441A (en) * | 2019-02-28 | 2020-09-03 | 沖電気工業株式会社 | Roadside machine and roadside machine system |
| JP7246218B2 (en) * | 2019-03-19 | 2023-03-27 | 株式会社小松製作所 | WORK SITE MANAGEMENT SYSTEM AND WORK SITE MANAGEMENT METHOD |
-
2022
- 2022-06-10 JP JP2022094268A patent/JP2023180726A/en active Pending
-
2023
- 2023-04-25 EP EP23819526.7A patent/EP4535331A4/en active Pending
- 2023-04-25 WO PCT/JP2023/016290 patent/WO2023238539A1/en not_active Ceased
Also Published As
| Publication number | Publication date |
|---|---|
| JP2023180726A (en) | 2023-12-21 |
| EP4535331A4 (en) | 2025-10-15 |
| WO2023238539A1 (en) | 2023-12-14 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7657805B2 (en) | Method and apparatus for controlling an automated vehicle - Patents.com | |
| CN112810628B (en) | Vehicle Control Systems | |
| US11634154B2 (en) | System and method for driving guide | |
| US11059481B2 (en) | Vehicle control system, vehicle control method, and vehicle control program | |
| US11161512B2 (en) | Vehicle control system, vehicle control method, and vehicle control program | |
| US20190135281A1 (en) | Vehicle control device, vehicle control method, and recording medium | |
| US8571786B2 (en) | Vehicular peripheral surveillance device | |
| JP6821791B2 (en) | Vehicle control systems, vehicle control methods, and vehicle control programs | |
| US20200159234A1 (en) | Vehicle control device, vehicle control method, and storage medium | |
| CN112180911A (en) | Method for monitoring a control system of an autonomous vehicle | |
| US20210070289A1 (en) | Vehicle control device, vehicle control method, and storage medium | |
| KR102670950B1 (en) | Autonomous driving system based on C-ITS in irregular driving environment and method thereof | |
| CN112099483A (en) | Method for monitoring a positioning function in an autonomous vehicle | |
| CN112119433B (en) | Safeguarding and taking safety measures against dangerous points by vehicle warning | |
| JP2022031012A (en) | Server, vehicle, traffic control method, and traffic control system | |
| US12315373B2 (en) | Method for assisting a motor vehicle | |
| US20200234572A1 (en) | Platform and method for monitoring an infrastructure for transport vehicles, associated vehicle, transport system and computer program | |
| CN115454036A (en) | Remote operation request system, remote operation request method, and storage medium | |
| JP7650653B2 (en) | Road Traffic Control System | |
| JP2019501831A (en) | Navigation optimized for safety | |
| JP2009048564A (en) | Vehicle position prediction device | |
| JP7444736B2 (en) | traffic control system | |
| JP7469979B2 (en) | Vehicle Control Systems | |
| JP2024082330A (en) | Route determination device and automated driving system | |
| EP4535332A1 (en) | Supervision device, roadside machine, movement control system, program, movement control method, and moving body |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE INTERNATIONAL PUBLICATION HAS BEEN MADE |
|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20250102 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| DAV | Request for validation of the european patent (deleted) | ||
| DAX | Request for extension of the european patent (deleted) | ||
| A4 | Supplementary search report drawn up and despatched |
Effective date: 20250911 |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: G08G 1/16 20060101AFI20250905BHEP Ipc: G08G 1/09 20060101ALI20250905BHEP Ipc: G08G 5/00 20250101ALI20250905BHEP Ipc: G08G 1/01 20060101ALI20250905BHEP Ipc: G08G 1/00 20060101ALI20250905BHEP Ipc: G08G 1/0967 20060101ALI20250905BHEP Ipc: G05D 1/227 20240101ALI20250905BHEP |