EP0230638B1 - A system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system - Google Patents
A system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system Download PDFInfo
- Publication number
- EP0230638B1 EP0230638B1 EP86117873A EP86117873A EP0230638B1 EP 0230638 B1 EP0230638 B1 EP 0230638B1 EP 86117873 A EP86117873 A EP 86117873A EP 86117873 A EP86117873 A EP 86117873A EP 0230638 B1 EP0230638 B1 EP 0230638B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- block
- value
- injection
- fact
- supplementary
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired
Links
Images


Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02D—CONTROLLING COMBUSTION ENGINES
- F02D41/00—Electrical control of supply of combustible mixture or its constituents
- F02D41/008—Controlling each cylinder individually
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02D—CONTROLLING COMBUSTION ENGINES
- F02D41/00—Electrical control of supply of combustible mixture or its constituents
- F02D41/02—Circuit arrangements for generating control signals
- F02D41/04—Introducing corrections for particular operating conditions
- F02D41/10—Introducing corrections for particular operating conditions for acceleration
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02D—CONTROLLING COMBUSTION ENGINES
- F02D41/00—Electrical control of supply of combustible mixture or its constituents
- F02D41/30—Controlling fuel injection
- F02D41/32—Controlling fuel injection of the low pressure type
Definitions
- the present invention relates to a system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system, in particular a sequential and phased system.
- Such known control systems are, however, usually unsatisfactory principally because of the requirements for very rapid and precise correction, and this limits the performance during such transient phases of such electronic fuel injection systems which, in general, define a very precise and rapid control strategy for the operation of the engine in that there is an electronic central control unit which, in dependence on signals which it receives from the various sensors (principally sensors detecting the speed of rotation and the phase of the engine, and sensors detecting the pressure and temperature of the inducted air) determines for example the density of the air in the manifold and the speed of rotation of the engine and calculates, by interpolation on associated memorised mappings, the timing and the duration of the fuel injection to the injectors, as well as the ignition advance.
- sensors principally sensors detecting the speed of rotation and the phase of the engine, and sensors detecting the pressure and temperature of the inducted air
- systems for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic fuel injection system which systems include means for detecting, at each induction stroke of an associated cylinder of the engine, differences in the value of the pressure in the induction manifold with respect to the pressure value existing at the moment of detection for calculation of the normal injection time relating to the said cylinder, and in dependence on the value of the said difference, said means determine whether or not to enable a supplementary injection of fuel (See GA-A 2 053 511).
- FR-A 2 524 554 only teaches to extrapolate the pressure values, which might prevail during the intake stroke, from previous values.
- the object of the present invention is to improve the characteristic of rapid correction by the system, by allowing that the mixture strength be corrected directly in the first induction stroke following a variation in the quantity of air inspired, in the expectation that the correction calculated through the usual measurement of the variation in the butterfly valve be performed, through a performed calculation of said pressure difference.
- a system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system including means for de-- tecting at each induction stroke of a respective cylinder of the said engine differences (CORi) in the value of the pressure in the induction manifold with respect to the pressure value existing at the moment of the detection for calculation of the normal injection time (DJi) relating to the said cylinder, and in dependence on the value of the said difference determining whether or not to enable a supplementary injection (DJE) of fuel, characterized in that the said pressure difference (CORi) used for deciding whether a supplementary injection should be performed is the difference between the measured pressure used for calculating a basic injection amount and the pressure measured during the induction stroke in which said basic injection amount is sucked into a cylinder.
- an electronic fuel injection system for a heat engine 101 conveniently a four cylinder engine, shown partially and in section.
- This system includes a central electronic control unit 102 including, in a substantially known way, a microprocessor 121 and registers in which are memorised mappings relating to different operating conditions of the engine 101, as well as various counters, including a counter 122, and various read and write memory registers (RAM), including registers 123 and 124 in particular, each having four memory cells.
- This central control unit 102 receives signals from:
- Figure 4 illustrates at lines a and b the temporal sequence of signals S and C provided by the sensors 103 and 105 the operation of which has been described in detail in Italian Patent application No. 67512-A/85 filed 4 June 1985 by the same applicant, the contents of which are incorporated here simply by reference for the necessary parts.
- the signals S are therefore provided by the sensors 103 at, respectively, 10 ° and 100 ° in advance of the top dead centre point of each cylinder, which are indicated respectively with the letters Pi, P 2 , P 3 and P 4 for the cylinders 1, 2, 3 and 4 (as is visible in Figure 4g, in which the associated induction, compression, expansion and exhaust strokes are also indicated with the letters A, C, E, S).
- Figure 4b there is indicated the temporal sequence of signals C provided by the sensor 105, and the combination of the signals S and C determines the progressive content from 0 to 9 of a counter 122 the value of which therefore identifies the associated stroke condition of each cylinder.
- the reference numerals from 0 to 7 indicate the associated conditions of 100° or 10 ° of the compression, expansion, exhaust and induction strokes, which numbers, for a specific cylinder, correspond unequivocally with two respective predetermined numbers of the counter 122: for example --the number 8 in the counter 122 corresponds to the numbers 5, 3, 1 and 7 of the associated cylinders 3, 4, 2 and 1, which indicate that they are at 10 ° from the end of the respective exhaust, expansion, compression and induction strokes.
- the system of the present invention for rapid correction of the fuel mixture strength supplied to the engine 101, made necessary by transient variation conditions of the operating parameters, determined principally by opening or closure of the butterfly valve 112 by the driver, is therefore principally based on the measurement of the difference in the induction pressure existing at the moment in which the injection time is calculated, with respect to the induction pressure present at the moment when the mixture is effectively inspired and burnt; to this correction strategy there is further added a supplementary correction strategy deriving from the measurement of the position of butterfly valve 112 with respect to the position which this valve had in the preceding calculation conditions.
- the main correction strategy therefore effects a correction of the injection time by means of a supplementary injection of fuel, being based on the measurement of the difference between the value of the absolute pressure in the induction manifold 107 detected in correspondence with the signal S100 subsequent to the signal S10 at which is measured the value of the absolute pressure in the manifold 107 (which is utilised by the programme for calculating the injection time DJi) and the value of the pressure in the manifold 107 measured in correspondence with the signal S100 of the induction stroke of the cylinder involved; this latter value is, in fact, more indicative of the first relative to the calculation of the quantity of inducted air.
- the duration of the supplementary fuel injection is therefore calculated starting from the memorised value KAPPAi relating to that cylinder, and by multiplying it by the difference between the value of the pressure in the induction manifold 107 read half way through the induction stroke, and the value of the pressure memorised at signal S100 indicative of the pressure situation in the induction manifold 107 at the moment when the normal injection time is calculated; to this value there is added a further correction factor depending on the battery voltage necessary to obtain the effective control time for the injector 116 from the calculated supplementary injection time.
- the additional correction strategy consists on the other hand in measuring the increment of the angular position of the butterfly valve 112 at each engine stroke, in correspondence with each signal S10, and then calculating a quantity proportional to the required correction, indicated DMAPCi, which modifies the content, (DMAPC) of a memory cell, directly proportional to the correction to be effected, only if it is of greater magnitude.
- DMAPCi modifies the content
- This value DMAPC is decremented by predetermined values (KDR) at each predetermined engine stroke number, for example four, to obtain a decreasing injection enrichment with time in the instants subsequent to the transient. Subsequent transient conditions will replace the present enrichment only if they are of greater magnitude.
- a deceleration condition (reduction in the angular position of the butterfly valve 112) without this returning to the idling position, will not alter the correction in progress. On the other hand in conditions where the butterfly valve 112 returns to the idling position, any additional injection time is cancelled.
- An increased contribution to the injection time equivalent to that caused by an increase in the angular position of the butterfly valve 112 is calculated in the condition in which the idling control strategy of the engine 101 causes an induction of supplementary air through the valve 114 of considerable magnitude, in fact this induction could produce a significant weakening of the mixture, the injection time calculation programme not yet having the power to utilise the new induction pressure values.
- the nor- ma) injection time is therefore corrected in an additive form with an additional injection time calculated starting from the current value of the quantity DMAPC, transformed through suitable scale constants, and corrected in dependence on the water temperature of the engine through respective tabulated coefficients.
- FIG. 2 there is shown a block schematic diagram indicating the main correction strategy, which is repetitively performed by means of the microprocessor 121 of the central control unit 102 whenever a signal S provided by the rotation sensor 103 arrives at the central control u nit 102 itself.
- This therefore leads to block 201 which evaluates if the signal S has detected a signal S10: in the positive case the programme leads to a block 202 which tests if there is a cylinder in the stroke established for commencement of the normal injection time. In the negative case this leads to a block 203 which causes continuation of the programme, including calculation of the injection time (DJi) with the parameters detected in correspondence with the signal S10 which has caused commencement of the performance of the calculation programme itself.
- DJi injection time
- This block 203 also calculates the coefficient KAPPAi equal to the said injection time DJi divided by the value of the pressure in the induction manifold 107 detected by the sensor 106 in correspondence with the signal S10 upon commencement of the programme for calculation of the injection time and memorises this value KAPPi in a corresponding cell of the memory 124.
- this leads to a block 204 which checks if the previously calculated normal injection time has a duration certainly less than the interval between the current injection stroke and about half of the following induction stroke, so that the injector is certainly closed half way through this induction stroke to allow a possible supplementary injection of fuel in a correct manner, according to the correction system of the present invention, with the characteristics which will be described in more detail below.
- This block 204 therefore tests if the difference between the supplementary injection stroke (stroke 6) and the current injection stroke (in the specific case stroke 4) multiplied by the interval between the two signals S, is greater than a predetermined safety value at the current injection time.
- the block 206 leads to the block 203 which has the function of continuation of the calculation programme just described. If the block 201 detects the negative condition, that is to say in the presence of a signal S100, it leads to a block 208 which acquires through the sensor 106 the value of the pressure (MAPM) in the induction manifold 107 in correspondence with this signal S100. This then leads to a block 209 which memorises this pressure value detected by the block 208 in the memory 123 and in the cell TABMAPi corresponding to the cylinder i in which there has been, or there will be, controlled the injection of duration equal to DJi generated by the preceding signal S 10.
- the block 201 detects the negative condition, that is to say in the presence of a signal S100, it leads to a block 208 which acquires through the sensor 106 the value of the pressure (MAPM) in the induction manifold 107 in correspondence with this signal S100. This then leads to a block 209 which memorises this pressure value detected by the block 208 in the memory 123
- the block 209 leads to a block 210 which evaluates if EXT is equal to 1: in the negative case (which indicates that there is no enablement for supplementary fuel injection) the programme leads to a block 212 which puts the condition DJE equal to zero, and then leads to block 202, whilst in the positive case it leads to a block 213 which calculates the difference between the current pressure in the induction manifold, detected by the block 208, and the value, still in correspondence with the signal S100, which has been memorised in the register 123 relative to the cylinder which is now in the induction stroke, this difference, indicated CORi is equal to MAPM minus TABMAPi.
- the block 213 leads to a block 214 which tests if this value CORi is greater than a threshold value DMEX: in the negative case this leads to the block 212, whilst in the positive case it leads to a block 215 which calculates the value DJE which defines the supplementary fuel injection time.
- This value DJE is equal to the value KAPPAi memorised in the memory 124 and relative to the cylinder which is now in stroke 6 (halfway through the induction stroke) multiplied by the value CORi determined by the block 213, to which is added a value CORVAT which is a function of the voltage of the battery 115.
- the block 215 then leads to a block 217 which controls the supplementary fuel injection by means of the electronic injector 116 relative to that cylinder for the time DJE calculated by the block 215 in the cylinder in stroke 6.
- the block 217 leads then to a block 218 which puts DJE equal to zero and then returns to block 202.
- the rapid fuel mixture strength correction system of the present invention has a further mode of operation in dependence on the detection of the quantity of air provided to the induction manifold 107 through detection of the variation in the angular position of the butterfly valve 112 or the variation in the quantity of air introduced through the supplementary valve 114 which will now be analysed in detail with reference to Figures 3a and 3b.
- the operating programme of Figure 3 is performed at each signal S10 and leads to a block 250 which, in dependence on the value of the cooling water of the engine 101 detected by the sensor 110 controls the choice of the value of a first coefficient KDER from a respective table of four values memorised in ROM memory, and a coefficient CP from a second table of 16 values memorised in ROM memory.
- the block 250 leads to a block 251 which, in the associated memory registers which store memorised values of previously calculated parameters, effects the updating of these parameters, in particular, the angular position value (FARFI) of the butterfly valve 112 detected in the preceding cycle is updated so that the memorised value FARFI is put equal to FAROLD; the value of a parameter (DUTYT) calculated in the preceding cycle is also updated, which indicates the percentage of the time for which the valve 114 is activated and therefore the quantity of supplementary air supplied through this valve, the test for which has been described in Italian Patent application No. 67544-A/85 filed 11 June 1985 by the same applicant and the content of which is incorporated herein by simple reference for the parts necessary; the block 251 therefore puts the stored value DUTYT equal to DUTYTO.
- FARFI angular position value
- DUTYT parameter
- the block 251 leads to a block 252 which, through the potentiometer 111 acquires a new value (FARFI) of the angular position of the butterfly valve 112, and then leads to a block 253 which evaluates if this new value detected by the block 252 is greater than the value FAROLD) of the preceding cycle memorised in the block 251.
- FARFI new value of the angular position of the butterfly valve 112
- the programme leads to a block 254 which calculates the difference between the current value of the angular position of the butterfly valve 112 and the value in the preceding cycle, and therefore puts DFARF equal to FARFI minus FAROLD; the block 254 leads to a block 254 which evaluates if this difference DFARF is greater than a threshold value DFS: in the positive case it leads to a block 256 which calculates a parameter DMAPCI as a product of the difference value DFARF and a conversion constant KDALM. From the block 256 the programme leads to a block 257 which evaluates if the value DMAPCI calculated by the block 256 is greater than a current value DMAPC the variability of which will be illustrated further below.
- the programme leads on to a block 258 which evaluates if this value DMAPCI is less than or equal to a maximum limit value KMAPSS: in the negative case it leads to a block 259 which puts this value DMAPCI equal to the limit value KMAPSS and then passes on to a block 260 which puts the value DMAPC equal to the value DMAPCI, whilst in the case of the positive condition the block 258 leads directly to the block 260. From this block 260 it then passes to a block 262 which puts a parameter i equal to 4 and then leads on to a block 263 which calculates an additional injection time (DJA) equal to this value DMAPC times a constant KMPDIN, all multiplied by the parameter CP determined by the block 250.
- DJA additional injection time
- a block 264 which tests if the starting phase of the engine has finished, that is to say if the current speed of rotation (RPM) is greater than a threshold value (RPM1), and in the positive case leads on to a block 265 which calculates the total normal injection time (DJi) as a sum of the injection time (DJi) already calculated by the programme and the additional time (DJA) calculated by the block 263. From the block 265 it then leads to a block 266 for continuation of the calculation programme in the microprocessor 121.
- RPM current speed of rotation
- DJA additional time
- the negative condition is detected by the block 264 it leads to a block 268 which puts the condition DMAPC equal to zero and then to a block 269 which consequently puts the additional injection time (DJA) also equal to zero, and then leads on to a block 270 which puts the parameter i equal to 4 and then to the block 265.
- the negative condition is detected by the block 255 ( Figure 3a) it leads to a block 272 which checks if the value of the parameter DAMPC is equal to zero: in the positive case it leads to the block 269 for cancellation of the additional injection time, whilst in the negative case it leads to a block 274 ( Figure 3b) which decrements the parameter i by one unit, putting i equal to i minus 1.
- a negative condition detected by the block 253 that is, in the case that the angular position of the butterfly valve 112 is constant or decreasing, it leads to a block 280 which evaluates if the position of the butterfly valve 112 (FARFI) is the minimum value (FARSM) in the negative case that is to say, in conditions of a constant angular position of the butterfly valve 112 greater than the minimum, or decreasing to values greater than the minimum, it leads to the block 272, whilst in the positive condition, that is if the butterfly valve 112 is at the minimum, it leads to a block 281 which evaluates if the butterfly valve 112 was also in the minimum position in the preceding cycle, for which it evaluates if FAROLD is equal to FARSM.
- FARFI position of the butterfly valve 112
- FARSM minimum value
- next signal S10 0 it goes from the block 201 to the block 202 and from this to block 203 for performance of the calculation programme of the injection time DJ1.
- next signal S100 point 3 of Figure 4e
- block 209 which memorises the pressure value read by the sensor 106 in the register 123 associated with the time DJ1
- block 210 goes to block 213 which in this case also calculates the correction value CORi for the cylinder 1 equal to zero, the pressure still being unchanged, so that from block 214 it goes to block 212 and then to block 202 which detects that cylinder 3 is established in the injection phase.
- the next block 204 with the block 205 enables a possible supplementary injection of fuel into cylinder 3 (in the subsequent induction phase) and then goes on to block 206 which controls the normal injection for the time DJO in the cylinder 3, likewise memorising the value of KAPPAi relative to time DJO and the pressure value read on the signal S100 (instant 1 of Figure 4a) in memory cells relative to cylinder 3 in which injection has just been taking place.
- the block 210 detects the condition EX2 equal to 1 for the cylinder 3 now in phase 6 (half way through induction) previously determined by the blocks 204 and 205 in that the injection time DJO injected in that cylinder was sufficiently limited and therefore lead to block 213 which calculates the value CORO equal to the difference between the value MAPN at this instant 5 and that memorised in the cell TABMAP 3, read at instant 1 ( Figure 4e) corresponding to the consecutive signal S100 after signal S10 which has started the programme for calculation of DJO.
- the blocks 204 and 205 enable a possible supplementary injection of fuel in the subsequent induction phase for the cylinder 4 and memorise in cells related to the cylinder 4 the associated values of KAPPAi and pressure at S100 (instant 3 of Figure 4e).
- the block 213 detects the value zero so that the block 214 leads on to block 212 which puts the supplementary injection time equal to zero.
- the block 204 detects the negative condition so that the block 207, with the condition EXT equals 0, does not enable the supplementary fuel injection and at the subsequent signal S1 the programme transfers from block 210 to block 212.
- the programme leads from the block 253 to the block 280 and then to the block 272 which detects the negative condition so that, through the block 274, there is a progressive reduction in the parameter i at each engine stroke. Since i has been established equal to 4 by the block 262, for three successive strokes the block 275 leads to the block 263 and then to blocks 264 and 265 for the addition of the injection time DJA in the manner already described and is illustrated in Figure 4g for the successive cylinders 1,3 and 4.
- a reduction in the angular position of the butterfly valve 112 at instant 4 causes the strategy to pass from block 253 to block 280 and then to block 272, which detecting a reduction in the value DMAPC does not alter the performance of the calculation in progress so that it returns to the blocks 274 and 275 with the continuation of the progressive decrementing of the magnitude DMAPC until the instant 5 in which the butterfly valve 112 is released at the idling position (FARSM).
- FARSM idling position
Landscapes
- Engineering & Computer Science (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Mechanical Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Electrical Control Of Air Or Fuel Supplied To Internal-Combustion Engine (AREA)
Description
- The present invention relates to a system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system, in particular a sequential and phased system.
- As is known, following variations in the quantity of air inducted into the induction manifold of the engine, mainly because of the variation of the angular position of the butterfly valve connected to the accelerator, it is necessary to correct the fuel mixture strength in that the time for which the injector is open is determined by previously detected parameters which are therefore not the current values, after transients which settle down and which modify the value of the parameters themselves. To improve the speed of correction of the mixture strength there have been used systems which detect the variation in the angular position of the butterfly valve and modify the injection time as a result. Such known control systems are, however, usually unsatisfactory principally because of the requirements for very rapid and precise correction, and this limits the performance during such transient phases of such electronic fuel injection systems which, in general, define a very precise and rapid control strategy for the operation of the engine in that there is an electronic central control unit which, in dependence on signals which it receives from the various sensors (principally sensors detecting the speed of rotation and the phase of the engine, and sensors detecting the pressure and temperature of the inducted air) determines for example the density of the air in the manifold and the speed of rotation of the engine and calculates, by interpolation on associated memorised mappings, the timing and the duration of the fuel injection to the injectors, as well as the ignition advance.
- Therefore, there have been provided systems for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic fuel injection system, which systems include means for detecting, at each induction stroke of an associated cylinder of the engine, differences in the value of the pressure in the induction manifold with respect to the pressure value existing at the moment of detection for calculation of the normal injection time relating to the said cylinder, and in dependence on the value of the said difference, said means determine whether or not to enable a supplementary injection of fuel (See GA-A 2 053 511).
- As disclosed in GB-
A 2 053 511, to detect said pressure difference only previous pressure values are used, and FR-A 2 524 554 only teaches to extrapolate the pressure values, which might prevail during the intake stroke, from previous values. - However, the object of the present invention is to improve the characteristic of rapid correction by the system, by allowing that the mixture strength be corrected directly in the first induction stroke following a variation in the quantity of air inspired, in the expectation that the correction calculated through the usual measurement of the variation in the butterfly valve be performed, through a performed calculation of said pressure difference.
- According to the present invention, there is provided a system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system, including means for de-- tecting at each induction stroke of a respective cylinder of the said engine differences (CORi) in the value of the pressure in the induction manifold with respect to the pressure value existing at the moment of the detection for calculation of the normal injection time (DJi) relating to the said cylinder, and in dependence on the value of the said difference determining whether or not to enable a supplementary injection (DJE) of fuel, characterized in that the said pressure difference (CORi) used for deciding whether a supplementary injection should be performed is the difference between the measured pressure used for calculating a basic injection amount and the pressure measured during the induction stroke in which said basic injection amount is sucked into a cylinder.
- For a better understanding of the present invention a particular embodiment is now described, purely by way of example, with reference to the attached drawings, in which:
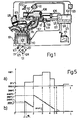
- Figure 1 is a schematic view of an electronic fuel injection system for a heat engine with the rapid fuel mixture strength correction system formed according to the present invention;
- Figure 2 is a flow chart illustrating a first part of the correction system of the present invention;
- Figures 3a and 3b illustrate flow charts of a second part of the correction system of the present invention;
- Figures 4a to 4g illustrate, in schematic form, various signals present in the electronic injection system with the correction system of the present invention; and
- Figures 5a and 5b illustrate, in schematic form, other signals present in the correction system of the present invention.
- With reference to Figure 1, there is schematically shown an electronic fuel injection system for a
heat engine 101, conveniently a four cylinder engine, shown partially and in section. This system includes a centralelectronic control unit 102 including, in a substantially known way, a microprocessor 121 and registers in which are memorised mappings relating to different operating conditions of theengine 101, as well as various counters, including acounter 122, and various read and write memory registers (RAM), includingregisters central control unit 102 receives signals from: - a
sensor 103 detecting the speed of rotation of theengine 101, disposed opposite apulley 104 having four equally spacedteeth 131 fitted to anengine shaft 125, - a
sensor 103 for detecting the phase of theengine 101, positioned in adistributor 126, - a
sensor 106 for detecting the absolute pressure existing in aninduction manifold 107 for theengine 101, - a
sensor 108 for detecting the temperature of the air in themanifold 107, - a
sensor 110 for detecting the temperature of the water in the cooling jacket of theengine 101, - a
sensor 111 substantially constituted by a potentiometer and angular position detector of abutterfly valve 112 disposed in theinduction manifold 107 and controlled by the accelerator pedal 113: - Before describing the operation of the correction system according to the present invention reference will be made to Figure 4 which illustrates at lines a and b the temporal sequence of signals S and C provided by the
sensors sensors 103 at, respectively, 10° and 100° in advance of the top dead centre point of each cylinder, which are indicated respectively with the letters Pi, P2, P3 and P4 for thecylinders sensor 105, and the combination of the signals S and C determines the progressive content from 0 to 9 of acounter 122 the value of which therefore identifies the associated stroke condition of each cylinder. As is visible in Figure 4g, the reference numerals from 0 to 7 indicate the associated conditions of 100° or 10° of the compression, expansion, exhaust and induction strokes, which numbers, for a specific cylinder, correspond unequivocally with two respective predetermined numbers of the counter 122: for example --the number 8 in thecounter 122 corresponds to thenumbers cylinders - In Figure 4f there is further shown, with a box, the calculation time of the main programme of the microprocessor 121, which starting from the detection of the signals from the various sensors, in correspondence with each S10, determines the normal injection time indicated DJi. Indicating with the numbers from 0 to 7 the various updated calculation programmes of the injection times (Figure 4f), in Figure 4g there are indicated the corresponding injection times (DJO, DJ1, DJ2, DJ3, DJ4 ...) which start from
number 4, corresponding to 100° of the exhaust stroke of each cylinder, supposing this injection phase to be established at an exemplary value of the engine speed of about 1400 revolutions per minute. - The system of the present invention for rapid correction of the fuel mixture strength supplied to the
engine 101, made necessary by transient variation conditions of the operating parameters, determined principally by opening or closure of thebutterfly valve 112 by the driver, is therefore principally based on the measurement of the difference in the induction pressure existing at the moment in which the injection time is calculated, with respect to the induction pressure present at the moment when the mixture is effectively inspired and burnt; to this correction strategy there is further added a supplementary correction strategy deriving from the measurement of the position ofbutterfly valve 112 with respect to the position which this valve had in the preceding calculation conditions. The main correction strategy therefore effects a correction of the injection time by means of a supplementary injection of fuel, being based on the measurement of the difference between the value of the absolute pressure in theinduction manifold 107 detected in correspondence with the signal S100 subsequent to the signal S10 at which is measured the value of the absolute pressure in the manifold 107 (which is utilised by the programme for calculating the injection time DJi) and the value of the pressure in themanifold 107 measured in correspondence with the signal S100 of the induction stroke of the cylinder involved; this latter value is, in fact, more indicative of the first relative to the calculation of the quantity of inducted air. During the performance of the programme for calculation and actuation of a certain injection time there is therefore memorised in a four cell memory, one for each cylinder, the value of the pressure in themanifold 107 in correspondence with signal S100 subsequent to the signal S10 at the beginning of the calculation programme, that is to say a pressure value very close to that utilised for the calculation of the injection time and can be correlated, for the same conditions, with the value of the pressure which will be measured half way through the induction stroke, also in correspondence with the signal S100; moreover, in the calculation programme there is stored a parameter KAPPAi equal to the calculated injection time DJi divided by the value of the pressure in theinduction manifold 107 in correspondence with the signal S10 at the commencement of calculation, this parameter KAPPAi is therefore proportional to the normal injection time in each cylinder, and will be utilised for the effective calculation of the necessary supplementary corrective injection. - Finally, at the moment of normal injection, which with reference to Figure 4 is supposed for example to be in
stroke 4, that is half way through the exhaust stroke, the possible supplementary corrective injection is effectively enabled, which will take place half way through the subsequent induction stroke, that is to say instroke 6, on condition that the normal injection time is reasonably less than the time available before the commencement ofstroke 6, for the purpose of avoiding the possibility that at the moment of supplementary injection of fuel the injector may be still open, which would result in an unwanted reduction of the main injection time. - The duration of the supplementary fuel injection is therefore calculated starting from the memorised value KAPPAi relating to that cylinder, and by multiplying it by the difference between the value of the pressure in the
induction manifold 107 read half way through the induction stroke, and the value of the pressure memorised at signal S100 indicative of the pressure situation in theinduction manifold 107 at the moment when the normal injection time is calculated; to this value there is added a further correction factor depending on the battery voltage necessary to obtain the effective control time for theinjector 116 from the calculated supplementary injection time. - The additional correction strategy consists on the other hand in measuring the increment of the angular position of the
butterfly valve 112 at each engine stroke, in correspondence with each signal S10, and then calculating a quantity proportional to the required correction, indicated DMAPCi, which modifies the content, (DMAPC) of a memory cell, directly proportional to the correction to be effected, only if it is of greater magnitude. This value DMAPC is decremented by predetermined values (KDR) at each predetermined engine stroke number, for example four, to obtain a decreasing injection enrichment with time in the instants subsequent to the transient. Subsequent transient conditions will replace the present enrichment only if they are of greater magnitude. A deceleration condition (reduction in the angular position of the butterfly valve 112) without this returning to the idling position, will not alter the correction in progress. On the other hand in conditions where thebutterfly valve 112 returns to the idling position, any additional injection time is cancelled. - An increased contribution to the injection time equivalent to that caused by an increase in the angular position of the
butterfly valve 112 is calculated in the condition in which the idling control strategy of theengine 101 causes an induction of supplementary air through thevalve 114 of considerable magnitude, in fact this induction could produce a significant weakening of the mixture, the injection time calculation programme not yet having the power to utilise the new induction pressure values. The nor- ma) injection time is therefore corrected in an additive form with an additional injection time calculated starting from the current value of the quantity DMAPC, transformed through suitable scale constants, and corrected in dependence on the water temperature of the engine through respective tabulated coefficients. - With reference to Figure 2, there is shown a block schematic diagram indicating the main correction strategy, which is repetitively performed by means of the microprocessor 121 of the
central control unit 102 whenever a signal S provided by therotation sensor 103 arrives at the central control unit 102 itself. This therefore leads toblock 201 which evaluates if the signal S has detected a signal S10: in the positive case the programme leads to ablock 202 which tests if there is a cylinder in the stroke established for commencement of the normal injection time. In the negative case this leads to ablock 203 which causes continuation of the programme, including calculation of the injection time (DJi) with the parameters detected in correspondence with the signal S10 which has caused commencement of the performance of the calculation programme itself. Thisblock 203 also calculates the coefficient KAPPAi equal to the said injection time DJi divided by the value of the pressure in theinduction manifold 107 detected by thesensor 106 in correspondence with the signal S10 upon commencement of the programme for calculation of the injection time and memorises this value KAPPi in a corresponding cell of thememory 124. In the event of a positive condition detected by theblock 202 this leads to ablock 204 which checks if the previously calculated normal injection time has a duration certainly less than the interval between the current injection stroke and about half of the following induction stroke, so that the injector is certainly closed half way through this induction stroke to allow a possible supplementary injection of fuel in a correct manner, according to the correction system of the present invention, with the characteristics which will be described in more detail below. Thisblock 204 therefore tests if the difference between the supplementary injection stroke (stroke 6) and the current injection stroke (in the specific case stroke 4) multiplied by the interval between the two signals S, is greater than a predetermined safety value at the current injection time. In the positive case this leads to ablock 204 which puts the condition EXT = 1, to enable a supplementary injection of fuel, and which memorises the value KAPPAi in a memory cell relating to the cylinder in which the main injection will be controlled to effect, in the case of transients, the calculation of the supplementary injection in that same cylinder; and then leads to ablock 206 which controls the normal injection of fuel in the pre-established stroke detected by theblock 202; in the case of the negative condition detected by theblock 204 this leads instead to ablock 207 which puts the condition EXT = 0, that is to say the supplementary injection of fuel is not enabled and then leads to theblock 206. - The
block 206 leads to theblock 203 which has the function of continuation of the calculation programme just described. If theblock 201 detects the negative condition, that is to say in the presence of a signal S100, it leads to ablock 208 which acquires through thesensor 106 the value of the pressure (MAPM) in theinduction manifold 107 in correspondence with this signal S100. This then leads to ablock 209 which memorises this pressure value detected by theblock 208 in thememory 123 and in the cell TABMAPi corresponding to the cylinder i in which there has been, or there will be, controlled the injection of duration equal to DJi generated by the precedingsignal S 10. - The
block 209 leads to ablock 210 which evaluates if EXT is equal to 1: in the negative case (which indicates that there is no enablement for supplementary fuel injection) the programme leads to ablock 212 which puts the condition DJE equal to zero, and then leads toblock 202, whilst in the positive case it leads to ablock 213 which calculates the difference between the current pressure in the induction manifold, detected by theblock 208, and the value, still in correspondence with the signal S100, which has been memorised in theregister 123 relative to the cylinder which is now in the induction stroke, this difference, indicated CORi is equal to MAPM minus TABMAPi. Theblock 213 leads to ablock 214 which tests if this value CORi is greater than a threshold value DMEX: in the negative case this leads to theblock 212, whilst in the positive case it leads to ablock 215 which calculates the value DJE which defines the supplementary fuel injection time. This value DJE is equal to the value KAPPAi memorised in thememory 124 and relative to the cylinder which is now in stroke 6 (halfway through the induction stroke) multiplied by the value CORi determined by theblock 213, to which is added a value CORVAT which is a function of the voltage of thebattery 115. Theblock 215 then leads to ablock 217 which controls the supplementary fuel injection by means of theelectronic injector 116 relative to that cylinder for the time DJE calculated by theblock 215 in the cylinder instroke 6. Theblock 217 leads then to ablock 218 which puts DJE equal to zero and then returns toblock 202. - As well as the operation determined by the detection of the variations in pressure in the
induction manifold 107 described with reference to Figure 2, the rapid fuel mixture strength correction system of the present invention has a further mode of operation in dependence on the detection of the quantity of air provided to theinduction manifold 107 through detection of the variation in the angular position of thebutterfly valve 112 or the variation in the quantity of air introduced through thesupplementary valve 114 which will now be analysed in detail with reference to Figures 3a and 3b. The operating programme of Figure 3 is performed at each signal S10 and leads to ablock 250 which, in dependence on the value of the cooling water of theengine 101 detected by thesensor 110 controls the choice of the value of a first coefficient KDER from a respective table of four values memorised in ROM memory, and a coefficient CP from a second table of 16 values memorised in ROM memory. Theblock 250 leads to ablock 251 which, in the associated memory registers which store memorised values of previously calculated parameters, effects the updating of these parameters, in particular, the angular position value (FARFI) of thebutterfly valve 112 detected in the preceding cycle is updated so that the memorised value FARFI is put equal to FAROLD; the value of a parameter (DUTYT) calculated in the preceding cycle is also updated, which indicates the percentage of the time for which thevalve 114 is activated and therefore the quantity of supplementary air supplied through this valve, the test for which has been described in Italian Patent application No. 67544-A/85 filed 11 June 1985 by the same applicant and the content of which is incorporated herein by simple reference for the parts necessary; theblock 251 therefore puts the stored value DUTYT equal to DUTYTO. - The
block 251 leads to a block 252 which, through thepotentiometer 111 acquires a new value (FARFI) of the angular position of thebutterfly valve 112, and then leads to ablock 253 which evaluates if this new value detected by the block 252 is greater than the value FAROLD) of the preceding cycle memorised in theblock 251. In the positive case the programme leads to ablock 254 which calculates the difference between the current value of the angular position of thebutterfly valve 112 and the value in the preceding cycle, and therefore puts DFARF equal to FARFI minus FAROLD; theblock 254 leads to ablock 254 which evaluates if this difference DFARF is greater than a threshold value DFS: in the positive case it leads to ablock 256 which calculates a parameter DMAPCI as a product of the difference value DFARF and a conversion constant KDALM. From theblock 256 the programme leads to ablock 257 which evaluates if the value DMAPCI calculated by theblock 256 is greater than a current value DMAPC the variability of which will be illustrated further below. In the positive case the programme leads on to ablock 258 which evaluates if this value DMAPCI is less than or equal to a maximum limit value KMAPSS: in the negative case it leads to ablock 259 which puts this value DMAPCI equal to the limit value KMAPSS and then passes on to ablock 260 which puts the value DMAPC equal to the value DMAPCI, whilst in the case of the positive condition theblock 258 leads directly to theblock 260. From thisblock 260 it then passes to ablock 262 which puts a parameter i equal to 4 and then leads on to ablock 263 which calculates an additional injection time (DJA) equal to this value DMAPC times a constant KMPDIN, all multiplied by the parameter CP determined by theblock 250. From theblock 263 it leads to ablock 264 which tests if the starting phase of the engine has finished, that is to say if the current speed of rotation (RPM) is greater than a threshold value (RPM1), and in the positive case leads on to ablock 265 which calculates the total normal injection time (DJi) as a sum of the injection time (DJi) already calculated by the programme and the additional time (DJA) calculated by theblock 263. From theblock 265 it then leads to ablock 266 for continuation of the calculation programme in the microprocessor 121. If the negative condition is detected by theblock 264 it leads to ablock 268 which puts the condition DMAPC equal to zero and then to ablock 269 which consequently puts the additional injection time (DJA) also equal to zero, and then leads on to ablock 270 which puts the parameter i equal to 4 and then to theblock 265. If the negative condition is detected by the block 255 (Figure 3a) it leads to ablock 272 which checks if the value of the parameter DAMPC is equal to zero: in the positive case it leads to theblock 269 for cancellation of the additional injection time, whilst in the negative case it leads to a block 274 (Figure 3b) which decrements the parameter i by one unit, putting i equal to i minus 1. From theblock 274 it leads tq ablock 275 which evaluates if the parameter i is equal to zero, and in the negative case leads to theblock 263, whilst in the positive case it leads to ablock 276 which decrements the value of the parameter DMAPC by the value KDER established by theblock 250, thus putting DMAPC equal to DMAPC minus KDER. Theblock 276 leads to ablock 277 which establishes the value of the parameter i equal to 4 and then leads to theblock 263. The programme arrives at thesame block 274 in the case of a negative condition detected by the block 257 (Figure 3a). - In the case of a negative condition detected by the
block 253, that is, in the case that the angular position of thebutterfly valve 112 is constant or decreasing, it leads to ablock 280 which evaluates if the position of the butterfly valve 112 (FARFI) is the minimum value (FARSM) in the negative case that is to say, in conditions of a constant angular position of thebutterfly valve 112 greater than the minimum, or decreasing to values greater than the minimum, it leads to theblock 272, whilst in the positive condition, that is if thebutterfly valve 112 is at the minimum, it leads to ablock 281 which evaluates if thebutterfly valve 112 was also in the minimum position in the preceding cycle, for which it evaluates if FAROLD is equal to FARSM. In the negative case, in which there has been a reduction in the angular position of thebutterfly valve 112 to the minimum value from the preceding cycle to the current cycle, it leads to ablock 268 for cancellation of the additional fuel injection, whilst in the case of the positive condition, that is to say, maintenance of the minimum position for a certain time, it leads to ablock 282 which evaluates a variation in the rate of flow of air through thevalve 114 as a difference between the current value of the parameter DUTYT and the value (DUTYTO) calculated in the preceeding cycle, and this difference is put equal to K Q which is then compared in asubsequent block 283 with a threshold value Qi. If the value detected by theblock 282 is less than this threshold value 0) no correction on the additional injection time is effected and the programme then leads on to block 272, whilst in the case of a positive condition detected by theblock 283 it leads to ablock 285 which calculates the value of the correction parameter DMAPCI as a product of the value K Q detected by theblock 282 and a transformation coefficient KDUMP, and then from theblock 285 leads to theblock 257. - A detail of the operating sequence of the correction system according to the present invention will now be described with reference to Figure 4, in - which the line d represents a step-like increase in the angular position of the
butterfly valve 112 starting from the idling position so there is a corresponding progressive increase in the pressure (MAPM) in theinduction manifold 107, indicated by the line e. Starting, for example, from the signal S10 corresponding to thepoint 0 of Figure 4e there is the commencement of the ZERO calculation programme (row 4f) and from block 201 (Figure 2) the programme leads to block 202 which, not detecting any cylinder in the established injection phase, sends to theblock 203 which proceeds to calculate the injection time DJO and the associated coefficient KAPPAi. At the next signal S100 (in the hypothesis of Figure 4 before the end of the calculation of DJO) it leads from theblock 201 to theblock 208 which detects the value of the pressure in the manifold 107 and memorises it by means of theblock 209 in thememory register cell 123 associated with the injection time DJO still in the calcuation phase. It then passes to theblock 210 and, supposing that the condition EXT is equal to 1, to theblock 213 which calculates the value CORi which, since there is not a pressure transient, is equal to zero. From theblock 214 it therefore leads to theblock 212 which puts the supplementary fuel injection time equal to zero and then leads to theblock 202 which detects if thecylinder 1 is in the established injection phase (stroke 4) from which it leads to block 204 which evaluates on the basis of the normal injection time for thecylinder 1 if this time is certainly less than the achievement of stroke 6 (half induction) for thecylinder 1 itself, and, in this case the positive condition being verified, since the duration of the injection time is indicated in broken lines in Figure 4g, it leads to block 205 which with the condition EXT equal to 1 enables a possible supplementary injection of fuel to thecylinder 1 itself. It then leads to block 206 which controls injection of the fuel for this time calculated in a stroke not present in Figure 4, indicated in broken outline, and then goes to block 203 for the continuation of the calculation programme for the normal injection time DJO. - At the
next signal S10 0 it goes from theblock 201 to theblock 202 and from this to block 203 for performance of the calculation programme of the injection time DJ1. At the next signal S100 (point 3 of Figure 4e) it goes to block 208 and then to block 209 which memorises the pressure value read by thesensor 106 in theregister 123 associated with the time DJ1, and then from theblock 210 goes to block 213 which in this case also calculates the correction value CORi for thecylinder 1 equal to zero, the pressure still being unchanged, so that fromblock 214 it goes to block 212 and then to block 202 which detects thatcylinder 3 is established in the injection phase. Thenext block 204 with theblock 205 enables a possible supplementary injection of fuel into cylinder 3 (in the subsequent induction phase) and then goes on to block 206 which controls the normal injection for the time DJO in thecylinder 3, likewise memorising the value of KAPPAi relative to time DJO and the pressure value read on the signal S100 (instant 1 of Figure 4a) in memory cells relative tocylinder 3 in which injection has just been taking place. At the next signal S10 which determines initiation of thecalculation programme 2, it goes from theblock 201 to theblock 202 and then to block 203 and then at the following signal S100 it goes fromblock 201 to block 208 which detects an increased value in the absolute pressure in the induction manifold 107 (instant 5 of Figure 4e) and this new value is memorised by theblock 209 in theregister cell 123 associated with the calculation time DJ2. Theblock 210 detects the condition EX2 equal to 1 for thecylinder 3 now in phase 6 (half way through induction) previously determined by theblocks instant 5 and that memorised in thecell TABMAP 3, read at instant 1 (Figure 4e) corresponding to the consecutive signal S100 after signal S10 which has started the programme for calculation of DJO. Supposing this value CORO to be greater than the threshold value DMEX, from theblock 214 it goes to block 215 which calculates the duration of this supplementary fuel injection equal to DJE as a product of the coefficient KAPPAi memorised in the calculation of the ZERO programme for thecylinder 3, for this value CORO and to which is added the corrective coefficient CORBAT. From theblock 215 it goes to the block 216 which detects thestroke 6 for thecylinder 3 and then theblock 217 controls opening of theinjector 116 relating to thiscylinder 3 for the calculated supplementary injection time DJE. From theblock 217 it then goes to theblock 218 which zeros this supplementary injection time, and then to theblock 202 which detects thecylinder 4 in the establishedinjection phase 4, for which the duration of the normal injection time DJ1 is controlled throughblock 206. In this case too, theblocks cylinder 4 and memorise in cells related to thecylinder 4 the associated values of KAPPAi and pressure at S100 (instant 3 of Figure 4e). Proceeding in a manner similar to that described, for the subsequent sequence of signals S10 and S100, as is visible in Figure 4g, one has that atinstant 7 for Figure 4e the magnitude of correction COR1 is calculated as the difference between the pressure signals at theinstants cylinder 4; similarly at instant 9 the pressure difference with respect toinstant 5 gives rise to the correction magnitude COR2 for the supplementary injection time DJE atstroke 6 forcylinder 2, and at instant 11 the pressure difference with respect toinstant 7, equal to the value COR3, gives rise to the supplementary injection time DJE atstroke 6 forcylinder 1. Subsequently, at instant 13, since there is no longer a pressure difference with respect to instant 9, theblock 213 detects the value zero so that theblock 214 leads on to block 212 which puts the supplementary injection time equal to zero. On the other hand, if the normal injection time is rather long, so as to terminate almost half way through the induction stroke, theblock 204 detects the negative condition so that theblock 207, with the condition EXT equals 0, does not enable the supplementary fuel injection and at the subsequent signal S1 the programme transfers fromblock 210 to block 212. - The intervention of the additional correction strategy, as a function of the detection of the variation in the angular position of the
butterfly valve 112, is described in detail with reference to Figures 3a and 3b. At the instants zero and 2 of Figure 4e in which thebutterfly valve 112 is maintained in the idling position, fromblock 253 the programme passes to block. 280 and from this to block 281 and 282 which supposes that no variation in the rate of flow of additional air through thesupplementary valve 114 is detected. Fromblock 283 it then passes to block 272 which detects the condition DMAPC equal to zero, and from this leads on to block 269 which puts the duration of the additional injection time DJA equal to zero so that theblock 265 does not alter the calculated value of the normal injection time DJi. At the next signal S10 (instant 47 the bloc k 252 detects an increased value of FARFI so that fromblock 253 it leads toblocks block 256 it leads to block 257 and then to theblocks block 262 leads to block 263 which calculates the value DJA equal to the additional injection time. Supposing that the starting phase of the engine has passed, fromblock 264 it leads to block 265 which at the normal injection time (DJ2) relating to programme two in operation atinstant 4, adds the additional time DJA calculated by thisblock 263, as is visible in Figure 4g, for thecylinder 2. Supposing that thebutterfly valve 112 remains constantly open at this increased opening value, at each signal S10 the programme leads from theblock 253 to theblock 280 and then to theblock 272 which detects the negative condition so that, through theblock 274, there is a progressive reduction in the parameter i at each engine stroke. Since i has been established equal to 4 by theblock 262, for three successive strokes theblock 275 leads to theblock 263 and then toblocks successive cylinders block 275 to block 276 which decrements the value of the magnitude DMAPC of the quantity KDER so that there is a reduction in the value of the additional injection time DJA calculated by theblock 263 and which in theblock 265 is added to the normal injection time DJ6 for the total time of injection to thecylinder 2. This new value DMAPC and therefore DJA also remain constant for four strokes, and then decrement again by the quantity KDER as already described. - The operation of this additional correction strategy in dependence on the position of the
butterfly valve 112 is further illustrated in a more complete manner for the different possible situations in Figure 5, in which, in Figure a there are indicated various successive butterfly positions, whilst in Figure b there is indicated the temporal progression of the corresponding quantity DMAPC. In the section from zero to 1 in which thebutterfly 112 is in the idling position FARSM, the value DMAPC also remains at zero; then, at the instant 1, with the increase in the position of thebutterfly valve 112 greater than the threshold value DFS, the control strategy goes from block 253 (Figure 3a) throughblocks block 256 which calculates the value DMAPC1. Fromblock 257 it goes to block 258 and then to block 260 which throughblock 262 goes on to block 263 for the calculation of the additional injection time DJA in the manner already described. As is illustrated in Figure 5b, with reference to what has already been described hereinabove, the value of the magnitude DMAPC reduces by the quantity KDER every four engine strokes until it arrives at the instant 2 in which there is a new increase (5a) in the angular position of thebutterfly valve 112. Fromblock 253 it therefore goes to block 254 and then to block 255 which detects the passing of the increasing threshold so that theblock 256 calculates a new value DMAPC2. Since theblock 257 detects that this new value DMAPC2 is greater than the current value DMAPC (Figure 5b, instant 2) fromblock 257 it goes to block 258 and then to block 260 and throughblock 262 causes with block 263 a new calculation of the additional injection time DJA starting from this new value DMAPC2, with the subsequent decrease in the value KDER every four engine strokes as already described hereinabove. Atinstant 3 in which there is a new increase in the angular position of the butterfly valve 112 (Figure 5a) fromblock 253 it goes again toblocks block 257 detects that the value DMAPC3 is less t han the current value DMAPC, the performance of the calculation in progress is not altered and therefore fromblock 257 it goes toblocks block 276 cause the value DMAPC to be reduced by the quantity KDER. A reduction in the angular position of thebutterfly valve 112 at instant 4 (Figure 5a) causes the strategy to pass fromblock 253 to block 280 and then to block 272, which detecting a reduction in the value DMAPC does not alter the performance of the calculation in progress so that it returns to theblocks butterfly valve 112 is released at the idling position (FARSM). In this condition, fromblock 253 it goes to block 280 and then to block 281 which, in the case of the first detection of the achievement of the idling condition, passes to block 268 which cancels the value of the quantity DMAPC so that the value of the additional injection time DJA is nullified. If at instant 7 (Figure 5a) there is an increase in the angular position of thebutterfly valve 112 less than the threshold value DFS, fromblock 253 it goes to block 254 and then to block 255 which detects the negative condition so that it goes to block 272 which detects in turn the zeroing condition of the magnitude DMAPC, so that it leads to block 269 which maintains the value of the additional injection time at zero. On the other hand, if, for example, atinstant 6, in which thebutterfly valve 112 is in the idling position, by means of the idling regulation system described in the first specified Patent application by the same applicant, there is controlled an introduction of supplementary air through thevalve 114 in a sufficiently high quantity, fromblock 253 it goes to block 280 and then to block 281 which detecting the positive condition of maintenance of the idling position moves on to block 282 which detects this additional increase in flow rate through thevalve 114 and then leads on to block 283 which detects that this flow rate exceeds the threshold value AQ1 so that it goes on to block 285 which calculates the value DMAPCI indicated in broken outline in Figure 5b; the successive performance of the programme through theblocks 257 and so on is similar to what has already been described hereinabove, with the subsequent decrementing of the magnitude DMAPC every four engine strokes. - The advantages obtained with the rapid correction system of the fuel mixture strength supplied to a heat engine having an electronic injection system, in particular a sequential and phased system, are evident from what has been described, since through the main correction strategy which detects the pressure in the
induction manifold 107 during the induction stroke and its variation with respect to the detection for the calculation of the injection time already effected relative to this cylinder, it is possible to effect a correction with a possible supplementary injection of fuel in that induction stroke immediately following the variation in the quantity of air inducted to the engine, generally due to the variation in the angular position of thebutterfly valve 112. The additional strategy of increasing the normal injection time by a progressively decremented value as a function of the speed of rotation of the engine (number of engine strokes) is rather useful for improving the precision of correction.
between the zones of the
Claims (17)
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| IT67055/86A IT1187872B (en) | 1986-01-24 | 1986-01-24 | QUICK CORRECTION SYSTEM OF THE TITLE OF THE COMBUSTIBLE MIXTURE PROVIDED TO AN ENDOTHERMAL ENGINE INCLUDING AN INJECTION SYSTEM AND ELECTRONICS |
| IT6705586 | 1986-01-24 |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP0230638A2 EP0230638A2 (en) | 1987-08-05 |
| EP0230638A3 EP0230638A3 (en) | 1988-05-11 |
| EP0230638B1 true EP0230638B1 (en) | 1990-05-02 |
Family
ID=11299227
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP86117873A Expired EP0230638B1 (en) | 1986-01-24 | 1986-12-22 | A system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system |
Country Status (5)
| Country | Link |
|---|---|
| EP (1) | EP0230638B1 (en) |
| BR (1) | BR8700372A (en) |
| DE (1) | DE3670883D1 (en) |
| ES (1) | ES2014229B3 (en) |
| IT (1) | IT1187872B (en) |
Families Citing this family (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE3803952A1 (en) * | 1988-02-10 | 1989-08-24 | Pierburg Gmbh | METHOD FOR OPERATING AN ELECTRONICALLY CONTROLLED FUEL INJECTION DEVICE FOR INTERNAL COMBUSTION ENGINES |
| IT1266351B1 (en) * | 1993-05-17 | 1996-12-27 | Weber Srl | ELECTRONIC INJECTION TIME CALCULATION SYSTEM. |
| FR2709151B1 (en) * | 1993-08-20 | 1995-09-15 | Renault | Method for calculating the mass of air admitted into an internal combustion engine. |
| JP3302199B2 (en) * | 1994-10-05 | 2002-07-15 | 日野自動車株式会社 | Car console box |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US3842811A (en) * | 1969-07-29 | 1974-10-22 | Toyota Motor Co Ltd | Electric fuel injection control system for internal combustion engines |
| US4245605A (en) * | 1979-06-27 | 1981-01-20 | General Motors Corporation | Acceleration enrichment for an engine fuel supply system |
| JPS58172446A (en) * | 1982-04-02 | 1983-10-11 | Honda Motor Co Ltd | Internal combustion engine operating state control device |
| JPS606041A (en) * | 1983-06-15 | 1985-01-12 | Honda Motor Co Ltd | Fuel injection control method for multi-cylinder internal combustion engine |
-
1986
- 1986-01-24 IT IT67055/86A patent/IT1187872B/en active
- 1986-12-22 EP EP86117873A patent/EP0230638B1/en not_active Expired
- 1986-12-22 DE DE8686117873T patent/DE3670883D1/en not_active Expired - Lifetime
- 1986-12-22 ES ES86117873T patent/ES2014229B3/en not_active Expired - Lifetime
-
1987
- 1987-01-23 BR BR8700372A patent/BR8700372A/en not_active IP Right Cessation
Also Published As
| Publication number | Publication date |
|---|---|
| IT1187872B (en) | 1987-12-23 |
| EP0230638A2 (en) | 1987-08-05 |
| BR8700372A (en) | 1987-12-08 |
| DE3670883D1 (en) | 1990-06-07 |
| EP0230638A3 (en) | 1988-05-11 |
| IT8667055A0 (en) | 1986-01-24 |
| ES2014229B3 (en) | 1990-07-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US4658787A (en) | Method and apparatus for engine control | |
| US5540205A (en) | Air fuel ratio control | |
| US4448162A (en) | Optimum control for internal combustion engines | |
| JP2003519751A (en) | Method and apparatus for controlling an internal combustion engine | |
| US5664544A (en) | Apparatus and method for control of an internal combustion engine | |
| US4711200A (en) | Automotive-engine fuel supply system | |
| EP0215412B1 (en) | A system for correction of the fuel injection time, upon variations in altitude, for a heat engine having an electronic injection system | |
| EP0215411B1 (en) | A system for automatic control of the fuel mixture strength supplied in slow running conditions to a heat engine having an electronic fuel injection system | |
| US5255655A (en) | Fuel injection system for an internal combustion engine | |
| US4563994A (en) | Fuel injection control apparatus | |
| US4800860A (en) | Fuel injection control system for internal combustion engine with precisely engine load dependent fuel injection amount adjustment feature | |
| US6920862B2 (en) | Methods for controlling a fuel metering in the multiple injection operating mode | |
| EP0230638A2 (en) | A system for the rapid correction of the fuel mixture strength supplied to a heat engine having an electronic injection system | |
| US4977876A (en) | Fuel injection control system for internal combustion engine with fuel cut-off control at high engine speed range suppressive of recovery shock upon fuels resumption | |
| US4725954A (en) | Apparatus and method for controlling fuel supply to internal combustion engine | |
| US5211148A (en) | Method of and an apparatus for controlling assist air in an internal combustion engine | |
| US4706632A (en) | Fuel control apparatus for internal combustion engine | |
| US4957086A (en) | Fuel controller for an internal combustion engine | |
| GB2142165A (en) | Fuel supply control method for internal combustion engines at acceleration | |
| US4721086A (en) | System for controlling fuel injectors to open asynchronously with respect to the phases of a heat engine | |
| US4736722A (en) | System for automatically defining the minimum setting of an accelerator-controlled valve for supplying an internal combustion engine | |
| US4901699A (en) | System for controlling a fuel injection quantity and method therefor | |
| US4696272A (en) | Ignition timing control method for internal combustion engines at idle | |
| WO1994001669A1 (en) | Device and method of regulating the start of fuel injection in an otto engine | |
| EP0429460B1 (en) | A fuel injection system for an internal combustion engine |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Kind code of ref document: A2 Designated state(s): DE ES FR GB NL SE |
|
| PUAL | Search report despatched |
Free format text: ORIGINAL CODE: 0009013 |
|
| AK | Designated contracting states |
Kind code of ref document: A3 Designated state(s): DE ES FR GB NL SE |
|
| 17P | Request for examination filed |
Effective date: 19881103 |
|
| 17Q | First examination report despatched |
Effective date: 19890227 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): DE ES FR GB NL SE |
|
| REF | Corresponds to: |
Ref document number: 3670883 Country of ref document: DE Date of ref document: 19900607 |
|
| ET | Fr: translation filed | ||
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: SE Payment date: 19901203 Year of fee payment: 5 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: NL Payment date: 19901231 Year of fee payment: 5 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed | ||
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Effective date: 19911223 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Effective date: 19920701 |
|
| NLV4 | Nl: lapsed or anulled due to non-payment of the annual fee | ||
| EUG | Se: european patent has lapsed |
Ref document number: 86117873.9 Effective date: 19920704 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20011211 Year of fee payment: 16 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 20011227 Year of fee payment: 16 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 20011228 Year of fee payment: 16 Ref country code: DE Payment date: 20011228 Year of fee payment: 16 |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: IF02 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20021222 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20021223 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20030701 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20021222 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20030901 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FD2A Effective date: 20021223 |