CN219131036U - Numerical control winding and unwinding mechanism for wire electrode - Google Patents
Numerical control winding and unwinding mechanism for wire electrode Download PDFInfo
- Publication number
- CN219131036U CN219131036U CN202320391846.7U CN202320391846U CN219131036U CN 219131036 U CN219131036 U CN 219131036U CN 202320391846 U CN202320391846 U CN 202320391846U CN 219131036 U CN219131036 U CN 219131036U
- Authority
- CN
- China
- Prior art keywords
- motor
- wire
- wire electrode
- machine tool
- numerical control
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 230000007246 mechanism Effects 0.000 title claims abstract description 94
- 238000004804 winding Methods 0.000 title claims abstract description 19
- 238000003860 storage Methods 0.000 claims abstract description 49
- 238000005520 cutting process Methods 0.000 claims abstract description 24
- ZOKXTWBITQBERF-UHFFFAOYSA-N Molybdenum Chemical compound [Mo] ZOKXTWBITQBERF-UHFFFAOYSA-N 0.000 claims description 35
- 229910052750 molybdenum Inorganic materials 0.000 claims description 15
- 239000011733 molybdenum Substances 0.000 claims description 15
- RYGMFSIKBFXOCR-UHFFFAOYSA-N Copper Chemical compound [Cu] RYGMFSIKBFXOCR-UHFFFAOYSA-N 0.000 claims description 3
- 230000001154 acute effect Effects 0.000 claims description 3
- 230000006698 induction Effects 0.000 claims description 3
- 230000001939 inductive effect Effects 0.000 claims description 3
- 229910052802 copper Inorganic materials 0.000 claims description 2
- 239000010949 copper Substances 0.000 claims description 2
- 230000002829 reductive effect Effects 0.000 abstract description 2
- 230000009466 transformation Effects 0.000 abstract description 2
- 230000000149 penetrating effect Effects 0.000 description 11
- 210000001503 joint Anatomy 0.000 description 10
- 229910052751 metal Inorganic materials 0.000 description 8
- 239000002184 metal Substances 0.000 description 8
- 239000000919 ceramic Substances 0.000 description 7
- 238000009434 installation Methods 0.000 description 6
- 238000003754 machining Methods 0.000 description 4
- 238000010586 diagram Methods 0.000 description 2
- 238000004880 explosion Methods 0.000 description 2
- 239000012530 fluid Substances 0.000 description 2
- 239000000463 material Substances 0.000 description 2
- 238000000034 method Methods 0.000 description 2
- 230000009286 beneficial effect Effects 0.000 description 1
- 230000008602 contraction Effects 0.000 description 1
- 230000008094 contradictory effect Effects 0.000 description 1
- 238000005260 corrosion Methods 0.000 description 1
- 230000007797 corrosion Effects 0.000 description 1
- 238000010892 electric spark Methods 0.000 description 1
- 230000005611 electricity Effects 0.000 description 1
- 230000003628 erosive effect Effects 0.000 description 1
- 230000000670 limiting effect Effects 0.000 description 1
- 238000004519 manufacturing process Methods 0.000 description 1
- 239000007769 metal material Substances 0.000 description 1
- 230000002441 reversible effect Effects 0.000 description 1
Images




Landscapes
- Electrical Discharge Machining, Electrochemical Machining, And Combined Machining (AREA)
Abstract
The utility model discloses a wire electrode numerical control winding and unwinding mechanism which comprises a machine tool body, a first motor, a second motor and a telescopic mechanism fixedly arranged on the machine tool body, wherein the output end of the first motor is connected with a wire storage cylinder for winding and unwinding a wire electrode, the output end of the second motor is connected with a roller, the second motor is arranged at the telescopic end of the telescopic mechanism, the telescopic mechanism can stretch and drive the roller to move to be tangent with the outer wall of the wire storage cylinder, the second motor can drive the roller to rotate, and the roller can drive the wire storage cylinder to rotate. In the online cutting process, the first motor can rotate at a high speed, and the second motor is matched with the telescopic mechanism when in machine adjustment, so that the wire storage cylinder can be driven to rotate at a low speed, and numerical control adjustment is realized; compared with a servo motor, the scheme has lower cost, and can be directly additionally arranged on an old machine tool, so that the cost of technical transformation is reduced.
Description
Technical Field
The utility model relates to the technical field of wire electrode winding and unwinding mechanisms of wire cutting equipment, in particular to a wire electrode numerical control winding and unwinding mechanism.
Background
Numerical control wire cutting machining is a branch of electric spark machining, and is to cut a workpiece by spark discharge through a wire electrode (molybdenum wire, copper wire and galvanized wire). In numerical control wire cutting processing, the relative movement of a workpiece and a wire electrode is controlled by digital information, and the numerical control wire cutting processing device is commonly used for processing high-hardness materials, fine structures, complex shapes, high-precision dimension parts and high-surface-quality parts.
Numerical control wire cutting machines are generally classified into three types: a fast wire cutting machine, a medium wire cutting machine and a slow wire cutting machine; taking a fast wire-electrode cutting machine as an example, the electrode wire moves in a high-speed reciprocating manner, and the wire-electrode moving speed is 8-10 m/s. The working principle is as follows: the electrode wire passes through a small hole drilled in advance on a workpiece, the workpiece is driven by a wire cylinder to reciprocate alternately through a guide wheel, the workpiece is arranged on a conductive workbench through an insulating plate, and the conductive workbench moves in two coordinate directions of a horizontal plane X, Y respectively according to a given control program to synthesize any plane curve track. The pulse power supply applies pulse voltage to the electrode wire and the workpiece, the electrode wire is connected with the negative electrode of the pulse power supply, and the workpiece is connected with the positive electrode of the pulse power supply. When an electric pulse is generated, spark discharge is generated between the electrode wire and the workpiece, the instantaneous elbow at the center temperature of the discharge channel can reach more than 10000 ℃, the metal of the workpiece is melted at high temperature, even a small amount of the metal is gasified, the working fluid between the electrode wire and the workpiece is gasified at high temperature, and the gasified working fluid and the metal vapor instantaneously and rapidly expand and have the characteristic of explosion. The thermal expansion and the local micro explosion throw out the melted and gasified metal material to realize the electric erosion cutting processing of the workpiece material.
In view of the above structure, the existing numerical control wire cutting machine tool needs to manually thread, the thread threading needs professional operation, the process is complex, in the wire cutting machining process, if other cutting needs to be machined on the same workpiece, the worker is required to watch, the thread is threaded manually after waiting for cutting at a position, and the next round of cutting is finished, so that the production efficiency is low, and the machining cost is high.
Disclosure of Invention
The utility model mainly aims to provide a numerical control winding and unwinding mechanism for a wire electrode, which can be improved in structure on the basis of a common motor of an original machine tool and realize numerical control adjustment.
In order to achieve the above purpose, the utility model provides a wire electrode numerical control winding and unwinding mechanism, which comprises a machine tool body, a first motor, a second motor and a telescopic mechanism fixedly arranged on the machine tool body, wherein the output end of the first motor is connected with a wire storage cylinder for winding and unwinding a wire electrode, the output end of the second motor is connected with a roller, the second motor is arranged at the telescopic end of the telescopic mechanism, the telescopic mechanism can stretch and drive the roller to move to be tangent with the outer wall of the wire storage cylinder, the second motor can drive the roller to rotate, and the roller can drive the wire storage cylinder to rotate.
Further, the first motor is a common motor for the wire cutting machine, and the second motor is a stepping motor.
Further, the machine tool body is movably connected with a motor mounting seat for mounting the first motor, the machine tool body is provided with a sliding driving mechanism for driving the motor mounting seat to slide, and the sliding direction of the motor mounting seat is perpendicular to the winding and unwinding direction of the wire electrode.
Further, the machine tool body is provided with an induction device for inducing the sliding position of the motor mounting seat.
Further, a clamping component for fixing the end part of the wire electrode is arranged on the outer wall of the wire storage cylinder.
Further, the clamping component is a flaky elastic clamping piece, one end of the elastic clamping piece is fixedly arranged on the outer wall of the yarn storage barrel, the other end of the elastic clamping piece is arranged along the outer wall of the yarn storage barrel in an extending mode, the tail end of the movable end of the elastic clamping piece extends outwards to form a guide end portion, and the guide end portion and a tangent plane of a clamping position of the outer wall of the yarn storage barrel form an acute angle.
Further, the wire electrode comprises molybdenum wires, copper wires and galvanized wires.
Compared with the prior art, the utility model has the following beneficial effects:
in the online cutting process, the first motor can rotate at a high speed, and the second motor is matched with the telescopic mechanism when in machine adjustment, so that the wire storage cylinder can be driven to rotate at a low speed, and numerical control adjustment is realized; compared with a servo motor, the scheme has lower cost, and can be directly additionally arranged on an old machine tool, so that the cost of technical transformation is reduced.
Drawings
In order to more clearly illustrate the embodiments of the present utility model or the technical solutions in the prior art, the drawings that are required in the embodiments or the description of the prior art will be briefly described, and it is obvious that the drawings in the following description are only some embodiments of the present utility model, and other drawings may be obtained according to the structures shown in these drawings without inventive effort for a person skilled in the art.
FIG. 1 is a schematic diagram of the overall structure of an embodiment of the present utility model;
FIG. 2 is an enlarged schematic view of portion a of FIG. 1;
FIG. 3 is a schematic view of a yarn storage mechanism according to an embodiment of the present utility model;
FIG. 4 is a schematic view of a movable tube set threading mechanism according to an embodiment of the present utility model;
FIG. 5 is an enlarged schematic view of portion b of FIG. 4;
FIG. 6 is a cross-sectional view showing an elongated state of the movable tube group according to the embodiment of the present utility model;
FIG. 7 is a cross-sectional view showing a contracted state of the movable tube group according to the embodiment of the present utility model;
FIG. 8 is a schematic diagram of a wiring state according to an embodiment of the present utility model;
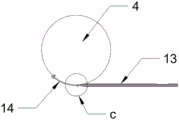
FIG. 9 is an enlarged schematic view of portion c of FIG. 8;
FIG. 10 is a schematic view of a clamping mechanism according to an embodiment of the present utility model;
reference numerals illustrate: 1-a first motor; 2-a second motor; 3-telescoping mechanism; 4-a yarn storage cylinder; 5-a roller; 6-a primary driving mechanism; 7-a secondary drive mechanism; 8-mounting a tube; 9-an outer tube; 10-an inner tube; 11-an elongated slot; 12-pins, 13-delivery tubes, 14-elastic clamping pieces, 15-butt tubes and 16-conductive blocks; 17-a connecting arm; 18-an elastic member; 19-guiding inclined plane; 20-a guide ramp; 21-ceramic eye mould; 22-wheel set mounting seats; 23-driving a motor; 24-driving a rotating shaft; 25-a drive gear; 26-driving the pinch wheel; 27-a driven rotating shaft; 28-driven gear; 29-a driven pinch wheel; 30-a translational drive mechanism; 31-a roller; a 32-L-shaped splint; 33-X axis mechanical arm; 34-Y axis mechanical arm; a 35-Z axis mechanical arm; 36-lifting mechanism; 37-a filar delivery catheter; 38-a first opening; 39-a second opening; 40-guiding end; 41-connecting pipes; 42-a motor mounting base; 43-slide drive mechanism.
Detailed Description
The following description of the embodiments of the present utility model will be made clearly and fully with reference to the accompanying drawings, in which it is evident that the embodiments described are only some, but not all embodiments of the utility model. All other embodiments, which can be made by those skilled in the art based on the embodiments of the utility model without making any inventive effort, are intended to be within the scope of the utility model.
It should be noted that all directional indicators (such as up, down, left, right, front, and rear … …) in the embodiments of the present utility model are merely used to explain the relative positional relationship, movement, etc. between the components in a particular posture (as shown in the drawings), and if the particular posture is changed, the directional indicator is changed accordingly.
Furthermore, the description of "first," "second," etc. in this disclosure is for descriptive purposes only and is not to be construed as indicating or implying a relative importance or implicitly indicating the number of technical features indicated. Thus, a feature defining "a first" or "a second" may explicitly or implicitly include at least one such feature. In addition, the technical solutions of the embodiments may be combined with each other, but it is necessary to base that the technical solutions can be realized by those skilled in the art, and when the technical solutions are contradictory or cannot be realized, the combination of the technical solutions should be considered to be absent and not within the scope of protection claimed in the present utility model.
Referring to fig. 1 to 9, the utility model provides an automatic wire cutting device, which comprises a machine tool, a wire storage mechanism, a movable tube group wire feeding mechanism, a clamping and conveying mechanism and a steering mechanism.
The machine tool comprises a machine tool body, a multi-axis mechanical arm and a processing platform, wherein the multi-axis mechanical arm and the processing platform are both arranged on the top surface of the machine tool body.
The wire storage mechanism comprises a first motor 1 (the first motor 1 in the embodiment is a common motor with a machine tool), a second motor 2 (the second motor 2 in the embodiment is a stepping motor additionally arranged at the later stage) and a telescopic mechanism 3 fixedly arranged on the machine tool body, the output end of the first motor 1 is connected with a wire storage cylinder 4 for winding and unwinding molybdenum wires, the output end of the second motor 2 is connected with a roller 5, the fixed end of the second motor 2 is arranged at the telescopic end of the telescopic mechanism 3, the telescopic mechanism 3 can extend to the roller 5 and is tangent to the outer wall of the wire storage cylinder 4, the second motor 2 can drive the roller 5 to rotate, the roller 5 can drive the wire storage cylinder 4 to rotate, the first motor 1 can rotate at a high speed in the linear cutting process, and the second motor 2 is matched with the telescopic mechanism 3 to drive the wire storage cylinder 4 to rotate at a slow speed so as to realize numerical control adjustment.
The machine tool comprises a machine tool body, wherein a motor mounting seat 42 for mounting a first motor 1 is movably connected to the machine tool body, a telescopic mechanism 3 is fixedly arranged on the motor mounting seat 42, a wire storage cylinder 4 is hinged to the motor mounting seat 42, a sliding driving mechanism 43 for driving the motor mounting seat 42 to slide is arranged on the machine tool body, and the sliding direction of the motor mounting seat is perpendicular to the winding and unwinding direction of a wire electrode. The machine tool body is provided with an induction device (not shown in the figure) for inducing the sliding position of the motor mounting seat, and when the wire storage cylinder 4 is wound and unwound and rotates, the sliding driving mechanism 43 drives the motor mounting seat 42 to translate, so that the wire storage cylinder 4 always does not deviate from a molybdenum wire clamping and conveying path when wound and unwound.
The movable tube group threading mechanism comprises a movable tube group with telescopic length, a multistage driving mechanism for driving the movable tube group, and a tube group installation seat fixedly connected with a machine tool body, wherein the movable tube group is of a hollow structure, the center of the movable tube group can be used for penetrating molybdenum wires, the movable tube group is movably installed along the length direction of the tube group installation seat, the multistage driving mechanism comprises a first-stage driving mechanism 6 capable of driving the movable tube group to integrally move and a second-stage driving mechanism 7 capable of driving the movable tube group to stretch, the movable tube group comprises an installation tube 8, a plurality of outer tubes 9 and a plurality of inner tubes 10, the outer tubes 9 and the inner tubes 10 are sleeved and connected in a head-tail mode, the outer walls of the outer tubes 9 are matched with the inner walls of the installation tube 8, the inner walls of the outer tubes 9 are matched with the outer walls of the inner tubes 10, the inner tubes 10 and the outer tubes 9 are movably arranged in the installation tube 8, the output ends of the first-stage driving mechanism 6 are fixedly connected to the outer walls of the installation tube 8 so as to drive the first-stage driving mechanism to integrally move, the outer walls of the inner tubes 10 are provided with concave long grooves 11, the side walls of the inner tubes 9 are provided with long grooves 12 which are correspondingly matched with the long grooves 11, and the inner tubes 11 are correspondingly arranged in the outer tubes 11, and the inner tubes are matched with one ends of the inner tubes 11, and the inner tubes are correspondingly provided with the long pins 11.
The movable tube group is close to one end of the wire storage cylinder 4 is provided with a delivery tube 13, the output end of the secondary driving mechanism 7 is fixedly connected to the outer wall of the delivery tube 13, so that the movable tube group is driven to stretch out and draw back through the delivery tube group, the molybdenum wire can be penetrated into the delivery tube 13 in a hollow mode, the tail end of the delivery tube 13 is provided with a tip, the wire storage cylinder 4 is provided with an elastic clamping piece 14, one end of the elastic clamping piece 14 is fixedly arranged on the outer wall of the wire storage cylinder 4 through a screw, the other end of the elastic clamping piece 14 extends along the outer wall of the wire storage cylinder 4, the tail end of the elastic clamping piece 14 is outwards extended to be provided with a guide end 40, the guide end 40 and a tangent plane at a clamping position of the outer wall of the wire storage cylinder 4 form an acute angle, and when the tip of the delivery tube 13 acts on the elastic clamping piece 14, the guide end 40 plays a guide role, and the tip is convenient to pry the elastic clamping piece 14 open to enable the tip to be in an open state.
When the wire storage cylinder 4 rotates to a preset position, the movable tube group can be extended to the point that the tip of the delivery tube 13 acts on the elastic clamping piece 14, under the guiding action of the guiding end part 40, the tip of the delivery tube 13 enables the elastic clamping piece 14 to elastically deform and expand, when the tip of the delivery tube 13 is separated from the clamping position of the elastic clamping piece 14 and the outer wall of the wire storage cylinder 4, the elastic clamping piece 14 is restored to the original clamping state, and the length of the delivery tube 13 is larger than the total expansion and contraction amount of the movable tube group, so that the molybdenum wire end part is prevented from falling into the middle of the movable tube group in the wire threading process and being blocked due to the concave position formed after extension.
The movable tube group is provided with a butt joint tube 15 near one end of the steering mechanism, a conductive mechanism is arranged between the movable tube group and the steering mechanism, the conductive mechanism comprises a conductive block 16 and a connecting arm 17, the conductive block 16 is arranged at one end of the connecting arm 17, the other end of the connecting arm 17 is hinged on a tube group mounting seat, an elastic piece 18 which drives the connecting arm 17 to rotate so as to enable the conductive block 16 to contact molybdenum wires is arranged between the tube group mounting seat and the connecting arm 17, when the conductive block 16 contacts the molybdenum wires, electric connection can be realized, one side of the connecting arm 17 near the molybdenum wires is provided with a guide inclined plane 19, one side of the butt joint tube 15 near the connecting arm 17 is provided with a guide inclined block 20 corresponding to the guide inclined plane 19, and when the guide inclined block 20 horizontally moves to the guide inclined plane 19, the connecting arm 17 can be driven to rotate so as to enable the conductive block 16 to be far away from the penetrating path of the molybdenum wire, a connecting pipe 41 is arranged between the conductive mechanism and the steering mechanism, one end of the connecting pipe 41 is in butt joint with the first opening 38, the other end of the connecting pipe corresponds to the butt joint pipe 15, two sides of the conductive mechanism are respectively provided with a ceramic eye mold 21, one ceramic eye mold 21 is arranged at the end part of the butt joint pipe 15, which is close to one side of the conductive mechanism, the other ceramic eye mold 21 is arranged at the end part of the connecting pipe 41, which is close to one side of the conductive mechanism, the aperture of the ceramic eye mold 21 is smaller than the aperture of the butt joint pipe 15 and the aperture of the connecting pipe 41, when the conductive block 16 is contacted with the molybdenum wire, the molybdenum wire is stressed to deflect downwards, the ceramic eye mold 21 plays a limiting role to prevent the molybdenum wire from damaging the butt joint pipe 15 during back and forth cutting, the connection pipe 41 and other parts on the molybdenum wire penetrating path.
The clamping mechanism comprises a wheel set mounting seat 22, a driving wheel set, a driven wheel set and a driving motor 23, the driving wheel set comprises a driving rotating shaft 24, a driving gear 25 and a driving clamping wheel 26, the driving rotating shaft 24 is hinged to the wheel set mounting seat 22, the driving gear 25 and the driving clamping wheel 26 are coaxially arranged on the driving rotating shaft 24, the driven wheel set comprises a driven rotating shaft 27, a driven gear 28 and a driven clamping wheel 29, the driven gear 28 and the driven clamping wheel 29 are coaxially arranged on the driven rotating shaft 27, one end of the driving rotating shaft 24 is connected with an output shaft of the driving motor 23, the driven rotating shaft 27 is connected with a translation driving mechanism 30, the translation driving mechanism 30 can drive the driven wheel set to translate so that the driving gear 25 is meshed with or separated from the driving gear 25, when the driving gear 25 is meshed with the driven gear 28, the driving motor 23 drives the driving rotating shaft 24 to rotate, at the moment, the driven gear 28 rotates reversely synchronously, and then drives the driving wheel 26 and the driven clamping wheel 29 to be reversely rotated synchronously with the driving wire clamp 29, and the driving wire clamp 29 rotates synchronously with the driving wire clamp 29.
The steering mechanism is arranged below the clamping mechanism, the steering mechanism and the movable tube group wire threading mechanism are at the same horizontal height, the steering mechanism comprises a roller 31 and an L-shaped clamping plate 32 matched with the roller 31, an arc-shaped guide groove matched with the outer wall of the roller 31 is formed in the inner side of the L-shaped clamping plate 32, a wire threading channel for threading molybdenum wires is formed between the guide groove and the outer wall of the roller 31, a first opening 38 is formed in one side of the movable tube group, a second opening 39 is formed in one side of the clamping mechanism, and the first opening 38 is perpendicular to the opening direction of the second opening 39.
The multi-axis mechanical arm comprises an X-axis mechanical arm 33, a Y-axis mechanical arm 34 and a Z-axis mechanical arm 35 which are fixedly arranged on a machine tool body, the Z-axis mechanical arm 35 is fixedly arranged on the top surface of the machine tool body and is vertical to the top surface of the machine tool body, the X-axis mechanical arm 33 is arranged on the Z-axis mechanical arm 35 and can slide along the Z-axis direction, the Y-axis mechanical arm 34 is arranged on the X-axis mechanical arm 33 and can slide along the X-axis direction, a lifting mechanism 36 is arranged below the Y-axis mechanical arm 34, the clamping mechanism is arranged at the lifting end of the lifting mechanism 36, a wire penetrating guide tube 37 is arranged below the clamping mechanism, molybdenum wires can be penetrated in the wire penetrating guide tube 37 in a hollow mode, and the wire penetrating guide tube 37 and the center of the second opening 39 are positioned on the same vertical line. The second opening 39, the port of the connecting pipe 41 near the side of the guiding mechanism, the ceramic eye mold 21, the port of the inner pipe 10 near the side of the butt joint pipe 15, the port of the delivery pipe 13 near the side of the movable pipe group, and the port of the threading conduit 37 near the clamping mechanism are all provided with funnel-shaped guiding ports, which have guiding function and facilitate the threading of molybdenum wires.
The working principle of the embodiment is as follows:
firstly, placing a metal workpiece to be cut on a processing platform and fixing the metal workpiece, enabling a processing hole position of the metal workpiece to be aligned with a second opening 39 of a steering mechanism, controlling a clamping mechanism to descend through a lifting mechanism 36, and enabling a wire penetrating guide tube 37 to descend to the processing hole position of the metal workpiece; at this time, the primary driving mechanism 6 drives the movable tube group to move to the abutting tube 15 to be engaged with the connecting tube 41, and at this time, the movable tube group is in a contracted state, and the connecting arm 17 rotates under the cooperation of the guide inclined surface 19 and the guide inclined block 20, so that the conductive block 16 is far away from the path of the penetrating molybdenum wire.
Then, the clamping mechanism is meshed with the driven gear 28 under the action of the translation driving mechanism 30, molybdenum wires are clamped between the driving clamping wheel 26 and the driven clamping wheel 29, clamping of the molybdenum wires is achieved under the action of the driving motor 23, meanwhile, the wire storage cylinder 4 and the clamping mechanism synchronously operate under the driving of the second motor 2, the end parts of the molybdenum wires penetrate out of the wire penetrating guide tube 37, enter the steering mechanism through the second opening 39, achieve 90-degree steering under the action of a wire penetrating channel formed by the guide groove and the outer wall of the roller 31, penetrate out of the first opening 38 and then enter the connecting tube 41, enter the movable tube group from the butt joint tube 15, penetrate through the end parts of the molybdenum wires after penetrating through the movable tube group and penetrate to the tip end of the delivery tube 13, and at this time, clamping of the molybdenum wires is suspended.
Then, the movable tube group is stretched under the action of the secondary driving mechanism 7, and the tip end of the delivery tube 13 acts on the elastic clamping piece 14 to enable the elastic clamping piece to elastically deform and expand; at this time, the wire storage cylinder 4 pauses rotating, and the clamping and conveying mechanism continues clamping and conveying the molybdenum wire, so that the end part of the molybdenum wire is clamped and conveyed to the clamping position of the elastic clamping piece 14 and the outer wall of the wire storage cylinder 4; then, the wire storage cylinder 4 is driven to rotate so that the tip end of the wire connecting tube 13 is withdrawn from the clamping position, the end part of the molybdenum wire is clamped at the clamping position of the elastic clamping piece 14 and the outer wall of the wire storage cylinder 4, automatic wire connection of the molybdenum wire is realized, the wire storage cylinder 4 is driven to rotate for a plurality of times so that the connection of the molybdenum wire and the wire storage cylinder 4 is firmer, and then the movable tube group is driven to shorten and reset.
Then, the telescopic mechanism 3 drives the roller 5 to be far away from the wire storage cylinder 4, the primary driving mechanism 6 drives the movable tube group to translate, so that the butt joint tube 15 is separated from the connecting tube 41, and at the moment, the connecting arm 17 rotates to the conductive block 16 to contact the molybdenum wire under the elastic reset action of the elastic piece 18, so that the electric connection is realized; the first motor 1 is started to enable the wire storage cylinder 4 to rotate at a constant speed in the forward direction/the reverse direction, and electric corrosion cutting is achieved under the action of pulse spark discharge.
After cutting is completed, the wire storage cylinder 4 rotates to an initial position, the movable tube group is horizontally moved by the first-stage driving mechanism 6 to act on the connecting arm 17 to enable the connecting arm to rotate, the conductive block 16 is separated from the molybdenum wire to disconnect electricity, then the movable tube group is stretched by the second-stage driving mechanism 7 to enable the tip end of the delivery tube 13 to act on the outer wall of the wire storage cylinder 4, the elastic clamping piece 14 is pried open, the end part of the molybdenum wire is loosened to clamp and retract the molybdenum wire, the disassembly of the molybdenum wire is completed, and the machined metal workpiece is taken away.
The foregoing description is only of the preferred embodiments of the present utility model and is not intended to limit the scope of the utility model, and all equivalent structural changes made by the description of the present utility model and the accompanying drawings or direct/indirect application in other related technical fields are included in the scope of the utility model.
Claims (7)
1. The utility model provides a wire electrode numerical control receive and releases mechanism, includes the lathe body, its characterized in that: the wire storage device comprises a machine tool body, and is characterized by further comprising a first motor, a second motor and a telescopic mechanism fixedly arranged on the machine tool body, wherein the output end of the first motor is connected with a wire storage cylinder for collecting and releasing a wire electrode, the output end of the second motor is connected with a roller, the second motor is arranged at the telescopic end of the telescopic mechanism, the telescopic mechanism can stretch and drive the roller to move to be tangent with the outer wall of the wire storage cylinder, the second motor can drive the roller to rotate, and the roller can drive the wire storage cylinder to rotate.
2. The numerical control wire electrode winding and unwinding mechanism according to claim 1, wherein: the first motor is a common motor for the wire cutting machine, and the second motor is a stepping motor.
3. The numerical control wire electrode winding and unwinding mechanism according to claim 1, wherein: the machine tool comprises a machine tool body, and is characterized in that a motor mounting seat for mounting the first motor is movably connected to the machine tool body, a sliding driving mechanism for driving the motor mounting seat to slide is arranged on the machine tool body, and the sliding direction of the motor mounting seat is perpendicular to the winding and unwinding direction of the wire electrode.
4. A wire electrode numerical control winding and unwinding mechanism as set forth in claim 3, wherein: the machine tool body is provided with an induction device for inducing the sliding position of the motor mounting seat.
5. The numerical control wire electrode winding and unwinding mechanism according to claim 1, wherein: the outer wall of the wire storage cylinder is provided with a clamping component for fixing the end part of the wire electrode.
6. The numerical control wire electrode winding and unwinding mechanism according to claim 5, wherein: the clamping assembly is a flaky elastic clamping piece, one end of the elastic clamping piece is fixedly arranged on the outer wall of the yarn storage barrel, the other end of the elastic clamping piece is arranged along the outer wall of the yarn storage barrel in an extending mode, the tail end of the movable end of the elastic clamping piece extends outwards to form a guide end portion, and the guide end portion and a tangent plane of a clamping position of the outer wall of the yarn storage barrel form an acute angle.
7. A wire electrode numerical control winding and unwinding mechanism according to any one of claims 1-6, characterized in that: the wire electrode comprises molybdenum wires, copper wires and galvanized wires.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202320391846.7U CN219131036U (en) | 2023-03-06 | 2023-03-06 | Numerical control winding and unwinding mechanism for wire electrode |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202320391846.7U CN219131036U (en) | 2023-03-06 | 2023-03-06 | Numerical control winding and unwinding mechanism for wire electrode |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN219131036U true CN219131036U (en) | 2023-06-06 |
Family
ID=86601265
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202320391846.7U Active CN219131036U (en) | 2023-03-06 | 2023-03-06 | Numerical control winding and unwinding mechanism for wire electrode |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN219131036U (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120920836A (en) * | 2025-10-15 | 2025-11-11 | 苏州宝玛格精密机械有限公司 | Electric spark wire winding and unwinding device and method convenient for automatic wire feeding |
-
2023
- 2023-03-06 CN CN202320391846.7U patent/CN219131036U/en active Active
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120920836A (en) * | 2025-10-15 | 2025-11-11 | 苏州宝玛格精密机械有限公司 | Electric spark wire winding and unwinding device and method convenient for automatic wire feeding |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN116252009B (en) | Automatic wire cutting equipment of threading | |
| CN107900168B (en) | left-right shared integrated numerical control pipe bender | |
| CN220330174U (en) | Automatic threading detection positioning mechanism | |
| US20120138576A1 (en) | Compound electrical discharge machining apparatus and small-hole electrical discharge machining module thereof | |
| CN219131035U (en) | Movable threading mechanism for multi-section pipe | |
| CN219131037U (en) | Movable tube group threading device | |
| CN117943645A (en) | Automatic wire-connection, wire-threading and wire-dismantling method of wire cutting equipment | |
| CN102205440B (en) | Linear groove processing method and device | |
| CN220330173U (en) | Numerical control wire storage mechanism for wire electrode | |
| CN220330176U (en) | Automatic wire threading, clamping and conveying mechanism for wire electrode | |
| CN219632773U (en) | Wire electrode dynamic adjusting device | |
| CN119407274A (en) | CNC wire feeding mechanism for automatic wire threading CNC wire EDM machine | |
| CN219304649U (en) | Split type stator coil numerical control bending machine | |
| CN220330175U (en) | Wire electrode multi-stage steering mechanism for wire cutting machine | |
| CN107186301A (en) | One kind is inverted to be exempted to wear thread feed electric spark wire electric discharge machine | |
| CN216325932U (en) | Tubular material feeding device of laser machine | |
| US20230059939A1 (en) | Channel machining equipment | |
| CN219324851U (en) | Wire electrode clamping and conveying butt joint device | |
| CN220921171U (en) | Automatic threading and butting mechanism | |
| CN118287775B (en) | Wire cutting equipment | |
| CN211700010U (en) | A winding system for processing coils | |
| CN221087528U (en) | Stable threading catheter lifting device | |
| CN120133625B (en) | A high-efficiency wire cutting machine for clamping and unclamping wires | |
| CN114985914A (en) | Cross sliding table laser cutting head | |
| CN216464145U (en) | Expanding type tool clamp |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |