CN217669470U - Special transport tongs of disc class part and disc class part transfer device - Google Patents
Special transport tongs of disc class part and disc class part transfer device Download PDFInfo
- Publication number
- CN217669470U CN217669470U CN202222058717.4U CN202222058717U CN217669470U CN 217669470 U CN217669470 U CN 217669470U CN 202222058717 U CN202222058717 U CN 202222058717U CN 217669470 U CN217669470 U CN 217669470U
- Authority
- CN
- China
- Prior art keywords
- disc
- opening
- parts
- bearing
- piece
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 230000007246 mechanism Effects 0.000 claims abstract description 21
- 230000005540 biological transmission Effects 0.000 claims abstract description 11
- 238000009434 installation Methods 0.000 claims description 15
- 230000003014 reinforcing effect Effects 0.000 claims description 4
- 230000000712 assembly Effects 0.000 claims 2
- 238000000429 assembly Methods 0.000 claims 2
- 238000004146 energy storage Methods 0.000 description 5
- 230000033001 locomotion Effects 0.000 description 5
- 230000009286 beneficial effect Effects 0.000 description 3
- 238000000034 method Methods 0.000 description 3
- 238000006243 chemical reaction Methods 0.000 description 2
- 230000008878 coupling Effects 0.000 description 2
- 238000010168 coupling process Methods 0.000 description 2
- 238000005859 coupling reaction Methods 0.000 description 2
- 230000004048 modification Effects 0.000 description 2
- 238000012986 modification Methods 0.000 description 2
- 238000010248 power generation Methods 0.000 description 2
- 229910000831 Steel Inorganic materials 0.000 description 1
- 230000002457 bidirectional effect Effects 0.000 description 1
- 229910052799 carbon Inorganic materials 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 238000004519 manufacturing process Methods 0.000 description 1
- 230000000149 penetrating effect Effects 0.000 description 1
- 238000000053 physical method Methods 0.000 description 1
- 230000008569 process Effects 0.000 description 1
- 238000007789 sealing Methods 0.000 description 1
- 239000010959 steel Substances 0.000 description 1
- 238000003860 storage Methods 0.000 description 1
- 238000005728 strengthening Methods 0.000 description 1
- 238000006467 substitution reaction Methods 0.000 description 1
- 239000000725 suspension Substances 0.000 description 1
Images


Classifications
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02E—REDUCTION OF GREENHOUSE GAS [GHG] EMISSIONS, RELATED TO ENERGY GENERATION, TRANSMISSION OR DISTRIBUTION
- Y02E60/00—Enabling technologies; Technologies with a potential or indirect contribution to GHG emissions mitigation
- Y02E60/16—Mechanical energy storage, e.g. flywheels or pressurised fluids
Landscapes
- Specific Conveyance Elements (AREA)
Abstract
The utility model discloses a special transferring gripper for disc parts, which comprises a mounting frame, an upper mounting part and a lower mounting part; the opening and closing structure is provided with a pair of opening and closing frames which have the same structure and are oppositely arranged; the clamping assembly is provided with at least two bearing parts for supporting the disc parts, the lower part of the vertical mounting part is provided with at least one bearing part, and the bearing parts are provided with bearing grooves matched with the circumferential edges of the disc parts; the power mechanism is in transmission connection with the two opening and closing frames and drives the two opening and closing frames to open and close so as to clamp the disc parts. The utility model utilizes the power mechanism to drive the two opening and closing frames to open and close, the supporting piece is positioned at the lower part of the opening and closing frames, and the disc parts can be upwards supported by the supporting piece; the disc type parts are transferred to the appointed stations by means of the robot or the lifting equipment, so that the disc type parts are automatically transferred, manual auxiliary operation is not needed, time and labor are saved, and the assembly efficiency is improved.
Description
Technical Field
The utility model belongs to the technical field of flywheel energy storage system's assembly and specifically relates to a special transport tongs of disc class part is related to still relate to a disc class part transfer device.
Background
The flywheel energy storage system stores energy by adopting a physical method, and realizes the mutual conversion and storage between electric energy and mechanical kinetic energy of a high-speed running flywheel through an electric/power generation mutual-inverse type bidirectional motor. At present, a flywheel energy storage system has the advantages of high energy density, high electric energy and mechanical energy conversion rate, high charging speed, maintenance-free, low-carbon and environment-friendly performances and the like, and is applied to the fields of aerospace, power grid peak shaving, wind power generation and the like.
The flywheel energy storage system is provided with a plurality of disc parts, such as a vacuum container, a suspension magnetic steel assembly, a sealing cover plate and the like which are arranged in the vacuum container, and the vacuum container and an assembled flywheel body need to be moved from an upper station to a lower station in the assembling process. At present, the transfer of a vacuum container and a flywheel body is realized by hoisting disc parts such as the container and the flywheel body by using a travelling crane and a lifting rope in a workshop mostly, the whole workpiece is heavy, the hoisting stability is poor, the damage is easily caused, and the safety is poor.
Disclosure of Invention
A first object of the utility model is to provide a special transport tongs of disc class part.
A second object of the utility model is to provide a disc class part transfer device to shift disc class part to next station from a station, and then realize automatic assembly.
In order to achieve the above purpose, the utility model adopts the following technical proposal:
special transport tongs of disc class part, include
The mounting frame is provided with an upper mounting piece and a lower mounting piece which are arranged at intervals up and down to form a mounting space;
the opening and closing structure is provided with a pair of opening and closing frames which have the same structure and are oppositely arranged, and each opening and closing frame is provided with a horizontal piece which horizontally moves back and forth in the installation space and a vertical installation piece which downwards extends from the outer end part of the horizontal piece;
the clamping assembly is provided with at least two bearing parts for supporting the disc type part, the lower part of the vertical mounting part is provided with at least one bearing part, and the bearing parts are provided with bearing grooves matched with the circumferential edge of the disc type part;
and the power mechanism is in transmission connection with the two opening and closing frames and drives the two opening and closing frames to open and close so as to clamp the disc parts.
The beneficial effects are that: the utility model utilizes the power mechanism to drive the two opening and closing frames to open and close, the supporting piece is positioned at the lower part of the opening and closing frames, and the disc parts can be upwards supported by the supporting piece; the disc type parts are transferred to the appointed stations by means of the robot or the lifting equipment, so that the disc type parts are automatically transferred, manual auxiliary operation is not needed, time and labor are saved, and the assembly efficiency is improved.
The utility model discloses an in the preferred embodiment, be provided with the slide rail on the installed part down, every the below of horizontal component be provided with slide rail complex sliding block set spare, the frame that opens and shuts passes through sliding block set spare along the slide rail level comes and goes. More preferably, the slide block assembly has a plurality of slide blocks moving along the slide rail and a connecting assembly provided on each slide block, the connecting assembly being fixedly connected with the horizontal member.
The beneficial effects are that: the utility model discloses utilize coupling assembling to link together slide rail and horizontal component, and then ensure that the horizontal component reciprocates along the slide rail level and remove, and then ensure the movement track of opening and shutting the frame.
In actual installation, the slide rails can be a pair, and each slide rail is provided with a slide block in a sliding manner (one slide block can be used when the length of the slide block is longer, and two slide blocks can be used when the length of the slide block is shorter), so that the motion track of the opening and closing frame is further ensured, and the stable movement of the opening and closing frame is ensured.
In other embodiments of the present invention, the power mechanism includes a pair of mounting seats with the same structure and a linear power source disposed on each of the mounting seats, and a power end of the linear power source is fixedly connected to the upper mounting member; and each horizontal piece is provided with an installation seat provided with the linear power source.
The beneficial effects are that: each opening and closing frame is in transmission connection with one of the linear power sources, and the two linear power sources synchronously move to realize automatic opening and closing of the opening and closing frames, so that the disc parts can be clamped and placed.
In actual installation, the linear power source is a horizontally installed cylinder, hydraulic cylinder or motor-driven transmission screw rod, and may be a horizontally installed cylinder, hydraulic cylinder or motor-driven transmission screw rod
In a preferred embodiment of the present invention, the connecting assembly includes a lower connecting member and an upper connecting member that are fixedly connected together, the upper connecting member is fixedly connected with the horizontal member, and the lower connecting member is connected with the slider. When the installation, set up on the horizontal part with connecting piece one-by-one complex logical groove down, ensure that the connecting piece lies in the logical inslot of horizontal part down to in fix the connecting piece down on the horizontal part, realize the fixed connection of coupling assembling and leading truck, ensure that the leading truck moves along the slide rail is stable, ensure the orbit that opens and shuts.
The utility model discloses an in a preferred embodiment, erect the muntin that the installed part is vertical setting, the muntin has two at least landing legs and will be two at least the horizontal strengthening rib that the landing leg links together, and every landing leg with strengthen the splice bar between the horizontal part, effectively guarantee the structural stability and the bearing performance of frame of opening and shutting.
The utility model discloses an in the preferred embodiment, every the bearing has the connecting portion of vertical setting and the supporting portion of level setting, the support groove sets up in the supporting portion, the bearing groove has bearing platform and side spacing face, the side spacing face is the arc structure unanimous with the circumferential edge reason structure of disc class part. By adopting the scheme, the side limiting surface and the bearing platform have limiting functions when the opening and closing frame is closed, the support and the limiting functions of the plurality of bearing pieces realize clamping of the disc parts, and the falling is effectively avoided.
The utility model also provides a disc class part transfer device, including the special transport tongs of robot and foretell disc class part, the special transport tongs setting of disc class part is at the link of robot, and it includes
The mounting frame is provided with an upper mounting piece and a lower mounting piece which are arranged at intervals up and down to form a mounting space;
the opening and closing structure is provided with a pair of opening and closing frames which have the same structure and are oppositely arranged, and each opening and closing frame is provided with a horizontal part which horizontally moves back and forth in the installation space and a vertical installation part which downwards extends from the outer end part of the horizontal part;
the clamping assembly is provided with at least two bearing parts for bearing the disc parts, the lower part of the vertical mounting part is provided with at least one bearing part, and the bearing parts are provided with bearing grooves matched with the circumferential edges of the disc parts;
the power mechanism is in transmission connection with the two opening and closing frames and drives the two opening and closing frames to open and close so as to clamp the disc parts.
In the above technical scheme: the connecting end of the robot is fixedly connected with a special transferring gripper for the disc parts, the robot can be used for driving the special transferring gripper for the disc parts to move flexibly, so that the automatic taking, placing and transferring of the disc parts are realized, manual auxiliary operation is not needed, time and labor are saved, and the assembly efficiency is improved;
in the above technical scheme: according to the layout of an assembly production line in a workshop, the robot can be a multi-axis robot (such as a six-axis robot), a base of the robot can be used as the center, and a special transfer gripper for disc parts is driven to adjust in the horizontal and height directions, so that the automatic transfer requirement is met; certainly, the robot can also be a truss manipulator, the truss manipulator is used for moving the special transferring gripper for the disc parts in the horizontal and height directions, the disc parts are transferred to the next station from one station, automatic taking and placing and transferring are achieved, and the working efficiency is improved.
Drawings
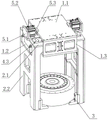
Fig. 1 is a schematic structural diagram of the present invention.
Fig. 2 is a bottom perspective view of the present invention (omitting the lower mounting plate and an opening and closing frame).
Fig. 3 is an isometric view of the present invention (one of the opening and closing frames is omitted).
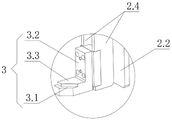
Fig. 4 is an enlarged view of a portion a in fig. 3.
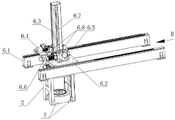
Fig. 5 is a schematic structural view of a second embodiment of the present invention.
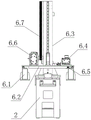
Fig. 6 is a view from direction B of fig. 5.
Detailed Description
The following describes embodiments of the present invention in detail with reference to the drawings, which are implemented on the premise of the technical solution of the present invention, and detailed embodiments and specific operation procedures are provided, but the scope of the present invention is not limited to the following embodiments.
Implementation mode one
As shown in figures 1-4, the special transferring gripper for disc parts of the present invention comprises
The mounting frame is provided with an upper mounting piece (namely the upper mounting plate 1.1, which can be a block or a seat of course), a lower mounting piece (namely the lower mounting plate 1.2, which can be a block or a seat of course) and a connecting piece (namely the connecting side plate 1.3) for connecting the upper mounting plate 1.1 and the lower mounting plate 1.2 together, wherein the upper mounting plate 1.1, the lower mounting plate 1.2 and the connecting side plate 1.3 enclose a mounting space with through grooves at two ends;
the folding structure is provided with a pair of folding frames 2 which have the same structure and are oppositely arranged, the folding frames 2 are provided with horizontal pieces (namely horizontal plates 2.1) which horizontally move back and forth in the installation space and vertical installation pieces (namely vertical frames) which extend downwards from the outer ends of the horizontal plates 2.1, and the vertical frames are fixed at the outer ends of the horizontal plates 2.1;
the clamping assembly is provided with a bearing piece (namely a bearing block 3) for lifting the disc type part, the lower part of each vertical frame is provided with the bearing block 3, and the bearing block 3 is provided with a bearing groove 3.1 matched with the circumferential edge of the disc type part;
the power mechanism is in transmission connection with the two opening and closing frames 2 and achieves taking and placing of the disc parts by driving the opening and closing frames 2 to open and close.
In the scheme, the power mechanism is in transmission connection with the opening and closing frame 2, and the power mechanism can drive the opening and closing frame 2 to be synchronously opened and closed, so that the supporting piece is positioned below the disc type part; the power mechanism drives the opening and closing frame 2 to be closed and reset synchronously, and the supporting piece is closed along with the opening and closing frame 2, so that the disc type parts are supported.
As shown in fig. 1-3, the lower mounting plate 1.2 is provided with a pair of strip-shaped supporting blocks 1.4, and each strip-shaped supporting block 1.4 is provided with a slide rail 4.1 extending along the length direction thereof. In the present embodiment, the two opening and closing frames 2 have the same structure, and the connection mode between the opening and closing frames 2 and the slide rails 4.1 is also the same. The connection between the opening and closing frame 2 on the left side and the sliding rail 4.1 is specifically explained as follows:
as shown in fig. 1-3, the opening and closing frame 2 has a horizontal plate 2.1 and a vertical frame connected together, a sliding block assembly is arranged below the horizontal plate 2.1 and matched with two sliding rails 4.1 one by one, the sliding block assembly comprises four sliding blocks 4.2 and a connecting assembly fixedly connected to the sliding blocks 4.2, and each sliding rail 4.1 is provided with two sliding blocks 4.2, so that the stress balance of the horizontal plate 2.1 is ensured, and the stable movement of the opening and closing frame 2 is realized;
the connecting assembly comprises four pairs of upper connecting pieces (namely upper connecting pieces 4.3) and lower connecting pieces (namely lower connecting pieces 4.4, the lower connecting pieces 4.4 are fixed on one of the sliding blocks 4.2) which are fixedly connected together, the horizontal plate 2.1 is clamped on the lower connecting pieces 4.4 and is fixed with the upper connecting pieces 4.3 together, and further the fixed connection of the sliding blocks 4.2, the connecting assembly and the horizontal plate 2.1 is realized, so that the opening and closing frame 2 horizontally moves back and forth along a pair of sliding rails 4.1 on the upper mounting plate 1.1, and the movement track of the opening and closing frame 2 is ensured;
the vertical frame of the opening and closing frame 2 is provided with two supporting legs 2.2 arranged at intervals and a plurality of transverse reinforcing ribs 2.3 for connecting the supporting legs 2.2 together, and the transverse reinforcing ribs 2.3 are arranged at intervals up and down to ensure the structural stability of the vertical frame; each supporting leg 2.2 and the horizontal plate 2.1 are connected together through a pair of reinforced connecting ribs 2.4 which are L-shaped structures, so that the structural stability and the bearing performance of the opening and closing frame 2 are ensured, and the clamping and transferring of disc parts are ensured.
As shown in fig. 3-4, a supporting member (i.e. a supporting block 3) is disposed at the lower portion of each leg 2.2, the supporting block 3 is in an L-shaped structure, and has a vertical connecting portion 3.2 (fixed on the leg 2.2) and a horizontal supporting portion 3.3, the supporting portion 3.3 has a supporting groove 3.1 for supporting the disc-like component, wherein the supporting groove 3.1 has a supporting platform engaged with the bottom surface of the disc-like component and a side limiting surface engaged with the circumferential side surface of the disc-like component and having an arc-shaped structure, and can support the edge portion of the disc-like component. In addition, the bearing blocks 3 on the two opening and closing frames 2 are correspondingly arranged left and right, so that the stable bearing of the disc parts is realized.
As shown in fig. 1, the power mechanism includes mounting seats 5.1 arranged opposite to each other in the left-right direction and linear power sources arranged on each mounting seat 5.1, and the two linear power sources are arranged opposite to each other in the left-right direction; the connection relationship between the linear power source and the opening and closing frame 2 will be described by taking the connection between the linear power source and the opening and closing frame 2 as an example:
as shown in fig. 1, the mounting seat 5.1 is disposed on a horizontal plate 2.1 of the opening and closing frame 2, and has a horizontal portion and a vertical portion, the linear power source is a cylinder 5.2 (which may be a hydraulic cylinder, of course) fixed on the horizontal portion, and a power end (i.e., a connecting end of a piston rod) of the cylinder 5.2 is fixed at a central position of a left side of the upper mounting plate 1.1 through a connecting block 5.3. When the folding and unfolding mechanism works, the end part of the piston rod is fixed on the upper mounting plate 1.1, when the piston rod extends out, the cylinder body of the air cylinder 5.2 drives the folding and unfolding frame 2 to move leftwards along the sliding rail 4.1 through the mounting seat 5.1, and similarly, the other air cylinder 5.2 drives the right folding and unfolding frame 2 to move rightwards along the sliding rail 4.1, so that the folding and unfolding frame 2 is in an opening state; when the piston rod of the cylinder 5.2 is retracted, the two cylinders 5.2 drive the two opening and closing frames 2 to synchronously move in opposite directions through the mounting seats 5.1 respectively, and further clamping of disc parts is achieved.
When the device is installed, a connecting flange can be installed on the upper installation plate 1.1 of the utility model, the utility model is fixed on a robot (such as a six-axis robot) by utilizing the connecting flange, and the utility model can be driven by the robot to move flexibly; also can be with the utility model discloses direct mount utilizes the truss manipulator to realize that this embodiment gets the nimble of putting anchor clamps and removes on assembly line's truss, and then shifts disc class part to next station by a station, realizes that disc class part's automatic clamp is got and is shifted.
Second embodiment
The transfer device for transferring the disc parts in the embodiment comprises a robot and the first transfer gripper special for the disc parts in the embodiment, wherein the robot is a truss manipulator, and the transfer gripper special for the disc parts is arranged on the truss manipulator. Specifically, the method comprises the following steps:
as shown in fig. 5-6, the truss manipulator is provided with a truss 6.1, a moving frame 6.2 horizontally moving along the truss 6.1 and a lifting frame 6.3 penetrating the moving frame 6.2, wherein the moving frame 6.2 is provided with a first power mechanism for enabling the moving frame to horizontally reciprocate along a slide rail 4.1 on the truss 6.1 and a second power mechanism for driving the special fixture for disc parts to lift; the special fixture for the disc parts is arranged below the lifting frame 6.3, and the second power mechanism is arranged on the moving frame 6.2 and is in transmission connection with the lifting frame 6.3, so that the special fixture for the disc parts and the moving frame 6.2 can indirectly move, and the special fixture for the disc parts can horizontally move back and forth along with the moving frame 6.2.
As shown in fig. 5-6, the first power mechanism includes a first motor 6.4 disposed on the moving frame 6.2 and a first gear driven by the first motor 6.4, a horizontal rack 6.5 is disposed on the truss, the first gear is engaged with the horizontal rack 6.5, and the first motor 6.4 is fixed on the moving frame 6.2. When the device works, the first motor 6.4 drives the movable frame 6.2 to horizontally move along the horizontal rack 6.5 through the first gear;
the second power mechanism comprises a second motor 6.6 arranged on the movable frame 6.2 and a second gear driven by the second motor 6.6, and the lifting frame 6.3 is provided with a vertical rack 6.7 meshed with the second gear. The second motor 6.6 is fixed on the moving frame, the lifting frame 6.3 penetrates through the moving frame, and the second motor 6.6 drives the lifting frame 6.3 to lift through the second gear, so that the lifting of the special transfer gripper for the disc parts is realized;
the first power mechanism and the second power mechanism realize that the special fixture for the disc parts moves in the horizontal and height directions, realize the flexible transfer of the disc parts among different stations, and realize automatic blanking and feeding so as to meet the continuous assembly requirement of the flywheel energy storage system.
As shown in fig. 5-6, the movable frame 6.2 is provided with a pair of limiting seats 6.8 matched with the slide rails on the lifting frame 6.3, so as to ensure the stable lifting of the lifting frame 6.3 and the special transfer gripper for disc parts.
When the disc part needs to be clamped, the special transferring gripper for the disc part (the initial state of the opening and closing frame 2 is the opening state) is moved to a first station of the part, the bearing part is ensured to be positioned below the part, the air cylinders 5.2 retract the piston rods, the cylinder bodies of the two air cylinders 5.2 drive the two opening and closing frames 2 to be closed simultaneously, the bearing blocks 3 move close to each other to realize the bearing of the disc part, and then the special transferring gripper for the disc part is moved to an appointed position of the next station by the truss manipulator; after reaching the designated position, the piston rod of the air cylinder 5.2 extends outwards to open the opening and closing frame 2, and then the part is placed at the designated position.
The utility model discloses an among other embodiments, according to workshop space and assembly line demand, the robot also can be multiaxis robot (like six robots), directly pass through flange with the disc class part special fixture of embodiment one and install on six robots can.
In the description of the present invention, unless otherwise expressly specified or limited, the terms "mounted," "connected," and "connected" when they are used are to be construed broadly, e.g., as meaning either a fixed connection, a removable connection, or an integral connection; can be mechanically or electrically connected; they may be connected directly or indirectly through intervening media, or they may be interconnected between two elements. The specific meaning of the above terms in the present invention can be understood by those skilled in the art through specific situations.
Finally, it should be emphasized that the above-described embodiments are merely preferred embodiments of the present invention, and not intended to limit the invention, and although the present invention has been described in detail with reference to the foregoing embodiments, it will be apparent to those skilled in the art that modifications and equivalents can be made without inventive faculty to the embodiments described in the foregoing description, or some of the technical features thereof may be substituted. Therefore, any modifications, equivalent substitutions, improvements, etc. made within the spirit and principle of the present invention should be included in the protection scope of the present invention.
Claims (10)
1. The utility model provides a special transport tongs of disc class part which characterized in that: comprises that
The mounting frame is provided with an upper mounting piece and a lower mounting piece which are arranged at intervals up and down to form a mounting space;
the opening and closing structure is provided with a pair of opening and closing frames which have the same structure and are oppositely arranged, and each opening and closing frame is provided with a horizontal piece which horizontally moves back and forth in the installation space and a vertical installation piece which downwards extends from the outer end part of the horizontal piece;
the clamping assembly is provided with at least two bearing parts for supporting the disc type part, the lower part of the vertical mounting part is provided with at least one bearing part, and the bearing parts are provided with bearing grooves matched with the circumferential edge of the disc type part;
the power mechanism is in transmission connection with the two opening and closing frames and drives the two opening and closing frames to open and close so as to clamp the disc parts.
2. The special transferring gripper for disc parts as claimed in claim 1, characterized in that: the lower mounting piece is provided with slide rails, a slide block assembly matched with the slide rails is arranged below each horizontal piece, and the opening and closing frame horizontally reciprocates along the slide rails through the slide block assemblies.
3. The special transferring gripper for disc parts as claimed in claim 2, characterized in that: the sliding block assembly is provided with a plurality of sliding blocks moving along the sliding rail and a connecting assembly arranged on each sliding block, and the connecting assemblies are fixedly connected with the horizontal member.
4. The special transferring gripper for disc parts as claimed in claim 3, characterized in that: the power mechanism comprises a pair of mounting seats with the same structure and a linear power source arranged on each mounting seat, and the power end of the linear power source is fixedly connected with the upper mounting piece; and each horizontal piece is provided with an installation seat provided with the linear power source.
5. The special transferring gripper for disc parts as claimed in claim 4, characterized in that: the linear power source is a horizontally arranged air cylinder, a hydraulic cylinder or a transmission screw rod driven by a motor.
6. The special transferring gripper for disc parts as claimed in claim 3, characterized in that: the connecting assembly comprises a lower connecting piece and an upper connecting piece which are fixedly connected together, the upper connecting piece and the horizontal piece are fixedly connected together, and the lower connecting piece is connected with the sliding block together.
7. The special transferring gripper for disc parts as claimed in claim 1, characterized in that: the vertical installation piece is a vertical frame which is vertically arranged, the vertical frame is provided with at least two supporting legs and at least two transverse reinforcing ribs which are connected together through the supporting legs, and each supporting leg is provided with a reinforcing connecting rib between the horizontal pieces.
8. The special transferring gripper for disc parts as claimed in claim 7, characterized in that: each bearing piece is provided with a connecting part which is vertically arranged and a bearing part which is horizontally arranged, each bearing groove is arranged on the corresponding bearing part and is provided with a bearing platform and a side limiting surface, and the side limiting surface is of an arc structure which is consistent with the circumferential edge structure of the disc part.
9. The utility model provides a disc class part transfer device, includes the robot, its characterized in that: the special transfer gripper for the disc type parts, disclosed by any one of claims 1 to 8, is further included and is arranged at the connecting end of the robot.
10. The disc-like part transfer device according to claim 9, wherein: the robot is a multi-axis robot or a truss manipulator.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202222058717.4U CN217669470U (en) | 2022-08-05 | 2022-08-05 | Special transport tongs of disc class part and disc class part transfer device |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202222058717.4U CN217669470U (en) | 2022-08-05 | 2022-08-05 | Special transport tongs of disc class part and disc class part transfer device |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN217669470U true CN217669470U (en) | 2022-10-28 |
Family
ID=83725708
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202222058717.4U Active CN217669470U (en) | 2022-08-05 | 2022-08-05 | Special transport tongs of disc class part and disc class part transfer device |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN217669470U (en) |
-
2022
- 2022-08-05 CN CN202222058717.4U patent/CN217669470U/en active Active
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN114725230A (en) | Photovoltaic module frame arranging machine, packaging equipment and packaging method | |
| CN206921934U (en) | A transplanting and stacking mechanism for soft-pack lithium battery modules | |
| CN114055486B (en) | Meal delivery robot and meal delivery method | |
| CN217675293U (en) | Disc piece overturning device for flywheel energy storage system assembly production line | |
| CN206153782U (en) | Battery welding equipment | |
| CN210413149U (en) | A mobile double welding robot workstation | |
| CN109301374B (en) | Disassembling mechanism for power battery module | |
| CN111300392A (en) | Mechanical arm for material transportation and working method thereof | |
| CN216442557U (en) | MGL-150 truss manipulator module | |
| CN223280470U (en) | A photovoltaic panel hoisting frame for photovoltaic power station construction | |
| CN112373715A (en) | Device for mounting wing leading edge component of large aircraft | |
| CN108975199A (en) | The automatic rising-sinking platform and elevator of a kind of quick operation and high accuracy positioning | |
| CN111591699A (en) | Broken rail type aerial track set receiving and dispatching mechanism | |
| CN112693921A (en) | Propelling adjusting device for heavy-load equipment to enter cabin | |
| CN221396835U (en) | Front auxiliary frame hoisting system | |
| CN113844321A (en) | Automatic battery replacement robot and battery replacement method | |
| CN115180378B (en) | Automatic overturning method for round part | |
| CN213916886U (en) | Clamping type assembling device for steel structure production | |
| CN216303078U (en) | Four-slide-rail type two-stage sliding lifting device | |
| CN112846629A (en) | Displacement turnover device | |
| CN223557704U (en) | Pressing nail assembling equipment | |
| CN223086908U (en) | Lifting plate returning machine positioning device | |
| CN223906034U (en) | Roof photovoltaic module transportation device | |
| CN219636297U (en) | Truss equipment | |
| CN206068869U (en) | A kind of suspender and material-transporting system |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |