CN215749137U - Small-sized dredging robot - Google Patents
Small-sized dredging robot Download PDFInfo
- Publication number
- CN215749137U CN215749137U CN202121693581.3U CN202121693581U CN215749137U CN 215749137 U CN215749137 U CN 215749137U CN 202121693581 U CN202121693581 U CN 202121693581U CN 215749137 U CN215749137 U CN 215749137U
- Authority
- CN
- China
- Prior art keywords
- frame structure
- submersible motor
- robot
- oil
- remote controller
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Withdrawn - After Issue
Links
- 239000003921 oil Substances 0.000 claims abstract description 37
- 230000007246 mechanism Effects 0.000 claims abstract description 16
- 239000010720 hydraulic oil Substances 0.000 claims abstract description 12
- 230000005540 biological transmission Effects 0.000 claims abstract description 8
- 238000004891 communication Methods 0.000 claims description 6
- 229910000831 Steel Inorganic materials 0.000 claims description 5
- 239000010959 steel Substances 0.000 claims description 5
- 238000003860 storage Methods 0.000 claims description 5
- 239000000498 cooling water Substances 0.000 claims description 2
- 230000001681 protective effect Effects 0.000 claims description 2
- XLYOFNOQVPJJNP-UHFFFAOYSA-N water Substances O XLYOFNOQVPJJNP-UHFFFAOYSA-N 0.000 description 19
- 239000010802 sludge Substances 0.000 description 6
- 238000010276 construction Methods 0.000 description 5
- 238000001514 detection method Methods 0.000 description 4
- 238000007689 inspection Methods 0.000 description 4
- 230000008859 change Effects 0.000 description 3
- 238000010586 diagram Methods 0.000 description 3
- 230000008901 benefit Effects 0.000 description 2
- 238000000034 method Methods 0.000 description 2
- 230000008569 process Effects 0.000 description 2
- 239000010865 sewage Substances 0.000 description 2
- 230000000007 visual effect Effects 0.000 description 2
- 230000009471 action Effects 0.000 description 1
- 230000002411 adverse Effects 0.000 description 1
- 239000010724 circulating oil Substances 0.000 description 1
- 238000001816 cooling Methods 0.000 description 1
- 230000008878 coupling Effects 0.000 description 1
- 238000010168 coupling process Methods 0.000 description 1
- 238000005859 coupling reaction Methods 0.000 description 1
- 238000005286 illumination Methods 0.000 description 1
- 238000011065 in-situ storage Methods 0.000 description 1
- 230000007774 longterm Effects 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 238000012544 monitoring process Methods 0.000 description 1
- 239000002699 waste material Substances 0.000 description 1
Images




Landscapes
- Manipulator (AREA)
Abstract
The utility model discloses a small-sized dredging robot, comprising: the walking unit comprises a frame structure, a walking mechanism and a hook; a transmission unit integrated on the frame structure, comprising: the submersible motor is connected with an external power supply through a waterproof cable; the frequency converter controls the submersible motor; the hydraulic oil pump is connected with the submersible motor, is connected with an oil tank and is communicated with the multi-way valve through an oil pipeline; the four groups of valves are communicated with the multi-way valve, wherein the two groups of valves are respectively connected with and drive the travelling mechanism; the other two groups of valves are respectively communicated with the two oil cylinders; the universal joints are respectively connected to the two oil cylinders; a vision unit comprising an LED lamp and a waterproof camera integrated on the frame structure; the execution unit is connected to the oil cylinder through a universal joint and drives the execution unit to move through the oil cylinder so as to clear the silt; the control unit comprises a receiver for receiving a control command sent by a remote controller and transmitting the control command to the corresponding unit.
Description
Technical Field
The utility model relates to a small-sized dredging robot.
Background
The drainage pipeline or box culvert is an engineering facility system for removing urban sewage, rainwater or rainwater on roads, and the facility systems are generally below the ground and have smaller space; after long-term operation, sludge and sundries are easy to accumulate in the facilities, and dredging is needed to ensure smooth drainage. The main difficulty of the dredging operation lies in that the operation environment is complex, constructors cannot go deep into the pipeline or the deep part of the box culvert, even if the constructors can go into the pipeline or the deep part of the box culvert for dredging, the manual dredging also reduces the working efficiency greatly, and the danger can be brought to the clearing personnel.
And to clearing up this kind of little space environment, adopt small-size robot to go the mediation, will significantly reduce adverse circumstances to constructor's harm, can also in time clear up the pipeline or the box culvert that easily silts up, block up, avoid causing sewage, rainwater to flow by the excessive routes to avoid polluted environment and influence traffic.
However, the existing dredging robot is large in size and cannot enter a small space for dredging; or the functions are single, the price is high, the cost for one time of use is high, the desilting is not carried out, and when the operation is not used, the resource waste is caused; in order to realize the purposes of low dredging cost in a small space and multifunction of one machine, a small dredging robot needs to be researched.
SUMMERY OF THE UTILITY MODEL
The application discloses small-size desilting machine people, its aim at solve the problem that current desilting machine human volume is huge and function singleness can't satisfy safe desilting in the narrow and small space.
In order to achieve the technical purpose, the following technical scheme is adopted in the application:
small-size desilting robot includes: the walking unit comprises a frame structure, a walking mechanism arranged at the bottom of the frame structure and a hook arranged at the tail end of the frame structure; a transmission unit integrated on the frame structure, the transmission unit comprising: the submersible motor is connected with an external power supply through a waterproof cable; the frequency converter is connected with and controls the starting and the stopping of the submersible motor; the hydraulic oil pump is connected with the submersible motor through a coupler, is connected with an oil tank and is communicated with the multi-way valve through an oil pipeline; the four groups of valves are communicated with the multi-way valve, wherein the two groups of valves are respectively connected with and drive the travelling mechanism; the other two groups of valves are respectively communicated with the two oil cylinders; the universal joints are respectively connected to the two oil cylinders; a vision unit comprising an LED lamp and a waterproof camera integrated on the frame structure; the execution unit is connected to the oil cylinder through a universal joint and drives the execution unit to move through the oil cylinder so as to carry out desilting; the control unit comprises a receiver for receiving a control command sent by a remote controller and transmitting the control command to the corresponding unit.
Preferably, the traveling mechanism comprises four wheel bodies and a steel crawler chassis covering the outer sides of the wheel bodies.
Preferably, the submersible motor is fixed at the middle position of the front end part of the frame structure; the frequency converter is arranged on one side of the rear end part of the frame structure; the multi-way valve and the oil pipeline are positioned on the other side of the rear end part of the frame structure; the hydraulic oil pump is arranged below the oil tank and behind the submersible motor.
Preferably, the number of the LED lamps is four, and the four LED lamps are respectively disposed at four corners of the frame structure.
Preferably, the two waterproof cameras are 360 degrees and are respectively arranged at the top of the frame structure; the remote controller is used for collecting underwater picture information and transmitting the picture information to the remote controller.
Preferably, a support is arranged on the frame structure, the universal joint is limited on the support, and the universal joint is communicated with the oil cylinder.
Preferably, the submersible motor is hermetically protected by a waterproof protective cover, and circulating cooling water is filled in the submersible motor.
Preferably, the remote controller is integrated with: the display screen is in signal connection with the waterproof camera and is used for displaying picture information transmitted by the waterproof camera; the two analog quantity linear handles are used for controlling the advancing and retreating of the travelling mechanism; the two switching value four-way rockers are used for matching with the two analog value linear handles to realize turning and pivot rotation of the walking mechanism; the operation indicator light is used for displaying the normal operation condition; the fault indicator light is used for displaying reminding during fault; the emergency stop rotating button is used for emergently stopping the operation of the robot; the starting/horn is used for making sound to display the working state when the normal dredging is in work; the frequency converter switch is electrically connected with and controls the rotating speed of the submersible motor; a shift switch button for controlling the speed of the traveling mechanism; the reserved switch button is used for reserving functions which need to be added by the robot later; the parameter debugging interface is used for connecting an external debugging machine; the parameter storage interface is used for storing data used by the remote controller; the wired communication interface is used for exchanging data with external equipment; and the power switch controls the on-off of the power supply of the remote controller.
Due to the adoption of the technical scheme, the small-sized dredging robot has the advantages of simple structure, exquisite layout and small size, can realize amphibious use, is convenient for replacing the execution equipment, and can realize multiple purposes.
Drawings
FIG. 1 is a first schematic structural diagram of an embodiment of the present application;
FIG. 2 is a second structural diagram of the present application;
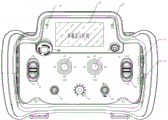
FIG. 3 is a schematic view of the structure of the remote control handle of the present application;
FIG. 4 is a schematic structural view of a remote control handle of the present application;
fig. 5 is a schematic structural diagram of a remote control handle according to the present application.
Detailed Description
The technical scheme of the utility model is further specifically described by the following embodiments and the accompanying drawings.
The small-sized dredging robot comprises a walking unit, a transmission unit, a visual unit, an execution unit and a control unit.
Referring to fig. 1 and 2, the walking unit includes a frame structure 2, a walking mechanism disposed below the frame structure 2, and a hook 11 disposed at a distal end of the frame structure 2. The walking mechanism comprises four wheel bodies and a steel crawler chassis 1 coated on the outer sides of the wheel bodies. The frame structure 2 provides an integrated place for the parts of other units, and the hook 11 is reserved for connecting a traction wire rope device in the later dredging process.
The transmission unit comprises a waterproof cable 10, a submersible motor 4, a frequency converter 5, a hydraulic oil pump 6, a multi-way valve 7, an oil pipeline 8, a hydraulic motor 3, an oil cylinder 9 and an oil tank 17. The vision unit comprises four LED lamps 14 and two 360 ° waterproof cameras 13. The execution units are two water cannons 12 which are arranged on the two oil cylinders 9. The control unit comprises a receiver 15 and a remote control 16.
The receiver 15 is integrated on the frame structure 2, and the remote controller 16 is integrated with a display screen 21, two analog quantity linear handles 22, two switching quantity four-way rockers 23, an operation indicator light 24, a fault indicator light 25, an emergency stop rotary button 26, a start/speaker 27, a frequency converter speed regulation switch 28, a speed change switch button 29, a reserved switch button 30, a parameter debugging interface 31, a parameter storage interface 32, a wired communication interface 33 and a power switch 34.
The transmission unit is installed on frame construction 2, and submersible motor 4 installs the position by desilting machine people front end in frame construction 2's centre, is connected with external power supply through waterproof cable 10, and submersible motor 4 gets up with the airtight safety cover of water proof safety cover, and the inside adds has the circulating water, and the circulating water is used for cooling down for submersible motor 4 for the robot can be under water, half water and land can both work. Submersible motor 4 starts through converter 5, converter 5 installs in frame construction's rear end one side, submersible motor 4 turns into kinetic energy with electric energy and drives hydraulic oil pump 6 and rotate, submersible motor 4 passes through shaft coupling 18 with hydraulic oil pump 6 and is connected, hydraulic oil pump 6 installs below oil tank 17, hydraulic oil pump 6 is at submersible motor 4's back, oil tank 17 provides circulating oil for hydraulic oil pump 6, hydraulic oil pump 6 produces high oil pressure and passes through oil pipe way 8 to multiple unit valve 7, multiple unit valve 7 is four groups of valves altogether, two sets of valves control hydraulic motor 3, hydraulic motor 3 redrives advancing, the backset of steel track chassis 1, the original place is rotatory and is turned. One hydraulic motor 3 rotates forwards, the other hydraulic motor 3 rotates backwards to control the steel crawler chassis 1 to rotate in place, and the other hydraulic motor 3 acts and the other hydraulic motor does not act to control the turning of the crawler chassis 1. The other two groups of valves control the action of the two oil cylinders 9, the parts of the oil cylinders 9 connected with the water cannon 12 are made into universal joints, and the water cannon 12 can be replaced by other dredging execution units or detection instruments, so that the function of one machine with multiple purposes is achieved.
Four LED lamps 14 among the visual unit are installed on four angles of frame construction 2, and LED lamp 14 is the illumination of desilting robot, and two 360 waterproof cameras are used for gathering picture information under water and transmit the display screen of remote controller on, the inside desilting operation condition of monitoring pipeline or box culvert.
The execution unit in the embodiment is two water cannons 12, the two water cannons 12 are installed on the oil cylinder 9, and the two oil cylinders 9 control the two water cannons 12 on the oil cylinder to move up and down, left and right to wash away sludge in a box culvert or a pipeline. The execution unit is not limited to a water cannon, and other dredging equipment or detection equipment is also possible.
The receiver 15 of the control unit is installed beside the frequency converter 5 and used for receiving the instruction sent by the remote controller 16 and transmitting the instruction to other units, and the remote controller 16 is integrated with a display screen 21, two analog quantity linear handles 22, two switching quantity four-way rockers 23, an operation indicator lamp 24, a fault indicator lamp 25, an emergency stop rotary button 26, a start/speaker 27, a frequency converter switch 28, a speed change switch button 29, a reserved switch button 30, a parameter debugging interface 31, a parameter storage interface 32, a wired communication interface 33 and a power switch 34.
The power switch 34 on the remote control 16 is used for starting a remote controller, the display screen 21 is used for displaying images of a dredging environment in real time, the two analog quantity linear handles 22 are used for controlling the advance and retreat of the robot, the two switching quantity four-way rocking rods 23 are matched with the two analog quantity linear handles 22 to realize the in-situ rotation and turning of the robot, the frequency converter switch 28 is used for controlling the rotating speed of the submersible motor 4, the speed change switch button 29 is used for controlling the walking speed of the robot, the reserved switch button is reserved for functions required to be added by the robot later, the operation indicator lamp 24 is used for displaying the normal operation condition of the robot, the fault indicator lamp 25 is used for prompting the fault condition of the robot, the emergency stop rotary button 26 is used for stopping the robot when the fault indicator lamp 25 is on or needs to stop, the start/horn 27 is used for sounding when the robot clears the silt, to show that the robot is working normally, the parameter debugging interface 31 is used to connect with the external debugging machine, the parameter storage interface 32 is used to store the data used by the remote controller, and the wired communication interface 33 is used to exchange data with the external equipment.
The small-sized dredging robot comprises the following operation steps:
when the dredging robot is used for dredging in a box culvert or a pipeline, firstly, a ground cover plate is opened during construction, the dredging robot is hoisted to a drainage pipeline or an inspection well of the box culvert by a crane, the dredging robot enters the box culvert, a diver assists in unfastening a crane rope buckle, a fire hose is connected to a high-pressure water truck, a waterproof cable 10 connected with the dredging robot is connected to an external ground power supply, a power switch 34 on a remote controller 16 is pressed, a submersible motor 4 is started through a frequency converter 5, the submersible motor 4 starts to rotate, the dredging robot is controlled to move towards the inside of the pipeline or the box culvert through the remote controller 16, the sludge at the bottom of the pipeline or the box culvert is washed by high-pressure water while walking, so that the sludge and sundries at the bottom are washed up, the washed-up sludge and sundries move forwards along the direction of water flow until the next inspection well, and workers clean the sludge and sundries at the inspection well, thus finishing a dredging process; the dredging robot retreats from the pipeline or the box culvert, continues to dredge forwards from the next inspection well, and repeats the steps until the dredging is finished; the dredging robot is smaller in size, the width and the height of the robot are not more than 1m, the robot is suitable for dredging in a small space, the submersible motor 4 is covered by circulating water and can cool the motor all the time, the robot can operate under the multi-working-condition environment condition, the connecting part on the oil cylinder 9 is a universal interface, the water cannon 12 is taken away, the robot can be replaced by execution equipment with other functions, for example, equipment in the aspect of detection can be replaced, the quality of underwater pipeline equipment can be detected, the operation task except dredging can be completed, and the multipurpose of one machine is really realized.
The utility model provides a compact structure, and the overall arrangement is exquisite, can reduce the shared volume of each part greatly, therefore has reduced whole volume relatively current robot. This application benefits from dive motor and water proof safety cover, can be applicable to different operational environment. And through the use of the universal joint, each execution unit and the detection equipment can realize the function of one machine with multiple functions.
The above-described embodiments are merely illustrative of the present invention and are not intended to limit the scope of the present invention. All equivalent changes and modifications of the utility model that may occur to those skilled in the art are intended to be covered by the appended claims.
Claims (8)
1. Small-size desilting robot, its characterized in that includes:
the walking unit comprises a frame structure, a walking mechanism arranged at the bottom of the frame structure and a hook arranged at the tail end of the frame structure;
a transmission unit integrated on the frame structure, the transmission unit comprising:
the submersible motor is connected with an external power supply through a waterproof cable;
the frequency converter is connected with and controls the starting and the stopping of the submersible motor;
the hydraulic oil pump is connected with the submersible motor through a coupler, is connected with an oil tank and is communicated with the multi-way valve through an oil pipeline;
the four groups of valves are communicated with the multi-way valve, wherein the two groups of valves are respectively connected with and drive the travelling mechanism; the other two groups of valves are respectively communicated with the two oil cylinders;
the universal joints are respectively connected to the two oil cylinders;
a vision unit comprising an LED lamp and a waterproof camera integrated on the frame structure;
the execution unit is connected to the oil cylinder through a universal joint and drives the execution unit to move through the oil cylinder so as to carry out desilting;
the control unit comprises a receiver for receiving a control command sent by a remote controller and transmitting the control command to the corresponding unit.
2. The small desilting robot as recited in claim 1, wherein the traveling mechanism includes four wheels and a steel crawler chassis covering the outside of the wheels.
3. The compact desilting robot as claimed in claim 1, wherein the submersible motor is fixed to a middle position of a front end portion of the frame structure; the frequency converter is arranged on one side of the rear end part of the frame structure; the multi-way valve and the oil pipeline are positioned on the other side of the rear end part of the frame structure; the hydraulic oil pump is arranged below the oil tank and behind the submersible motor.
4. The compact desilting robot as claimed in claim 1 or 3, wherein the number of the LED lamps is four, and the LED lamps are respectively arranged at four corners of the frame structure.
5. The small-sized dredging robot according to claim 1 or 3, wherein the waterproof cameras are two 360 ° waterproof cameras, and the two waterproof cameras are respectively arranged on the top of the frame structure; the remote controller is used for collecting underwater picture information and transmitting the picture information to the remote controller.
6. A compact dredging robot according to claim 1, wherein a support is provided on the frame structure, the universal joint being confined to the support, the universal joint being in communication with the cylinder.
7. The compact desilting robot as claimed in claim 1, wherein the submersible motor is hermetically protected by a waterproof protective cover, and the submersible motor is filled with circulating cooling water.
8. The compact desilting robot as recited in claim 1, wherein the remote controller is integrated with:
the display screen is in signal connection with the waterproof camera and is used for displaying picture information transmitted by the waterproof camera;
the two analog quantity linear handles are used for controlling the advancing and retreating of the travelling mechanism;
the two switching value four-way rockers are used for matching with the two analog value linear handles to realize turning and pivot rotation of the walking mechanism;
the operation indicator light is used for displaying the normal operation condition;
the fault indicator light is used for displaying reminding during fault;
the emergency stop rotating button is used for emergently stopping the operation of the robot;
the starting/horn is used for making sound to display the working state when the normal dredging is in work;
the frequency converter switch is electrically connected with and controls the rotating speed of the submersible motor;
a shift switch button for controlling the speed of the traveling mechanism;
the reserved switch button is used for reserving functions which need to be added by the robot later;
the parameter debugging interface is used for connecting an external debugging machine;
the parameter storage interface is used for storing data used by the remote controller;
the wired communication interface is used for exchanging data with external equipment; and
and the power switch controls the on-off of the power supply of the remote controller.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202121693581.3U CN215749137U (en) | 2021-07-26 | 2021-07-26 | Small-sized dredging robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202121693581.3U CN215749137U (en) | 2021-07-26 | 2021-07-26 | Small-sized dredging robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN215749137U true CN215749137U (en) | 2022-02-08 |
Family
ID=80107035
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202121693581.3U Withdrawn - After Issue CN215749137U (en) | 2021-07-26 | 2021-07-26 | Small-sized dredging robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN215749137U (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113510681A (en) * | 2021-07-26 | 2021-10-19 | 上海市水利工程集团有限公司 | Small-sized dredging robot |
-
2021
- 2021-07-26 CN CN202121693581.3U patent/CN215749137U/en not_active Withdrawn - After Issue
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113510681A (en) * | 2021-07-26 | 2021-10-19 | 上海市水利工程集团有限公司 | Small-sized dredging robot |
| CN113510681B (en) * | 2021-07-26 | 2024-05-17 | 上海市水利工程集团有限公司 | Small dredging robot |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN103672293B (en) | The amphibious working pipe pipeline robot of a kind of multi-dimensions test | |
| CN103672289B (en) | Pipeline robot with adjustable crawler belt angle | |
| CN203092545U (en) | Transformer station live working robot | |
| KR100920694B1 (en) | Car dredging dredging method using underwater robot dredger | |
| CN103672296B (en) | A kind of integrated frame type pipeline robot | |
| CN105500337B (en) | A comprehensive pipe corridor inspection robot | |
| CN104998850A (en) | Electrification water washing robot system of transformer substation and method | |
| CN103056866A (en) | Live-working robot of transformer substation | |
| CN105033984B (en) | Mobile automatic water-supplying transformer station living water washing robot system | |
| CN101982618A (en) | Manual control and remote control integrated electric fork lift truck | |
| CN102839703A (en) | Remote-control submerged underwater desilting vehicle | |
| KR20090052923A (en) | Remote Control Underwater Dredging Robot | |
| CN208033222U (en) | Pipeline dredging robot with ultrasonic-assisted crushing function | |
| CN210879631U (en) | Electricity drives portable tunnel excavation desilting industrial robot device | |
| CN109826307A (en) | A robot used for sludge cleaning of underground sewage pipes | |
| CN104999450A (en) | Electrification water washing auxiliary flushing robot system for mobile self-water-supply type transformer substation and method | |
| CN106193268A (en) | Amphibious multiple-unit wheeled pipe robot examination and repair system | |
| CN108442506A (en) | A kind of multi-functional detection robot for drainage pipeline | |
| CN105464162A (en) | Underwater dredging robot | |
| CN113510681A (en) | Small-sized dredging robot | |
| CN214252931U (en) | Wireless remote control system of scraper | |
| CN110722536A (en) | An electric-driven mobile tunnel excavation and dredging industrial robot device and method | |
| CN108867741A (en) | Amphibious dredging robot | |
| CN102995672A (en) | Multifunctional remote-controlled robot for mini-type engineering | |
| CN209817073U (en) | Hydraulic power track pump truck |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| AV01 | Patent right actively abandoned |
Granted publication date: 20220208 Effective date of abandoning: 20240517 |
|
| AV01 | Patent right actively abandoned |
Granted publication date: 20220208 Effective date of abandoning: 20240517 |
|
| AV01 | Patent right actively abandoned | ||
| AV01 | Patent right actively abandoned |