Tree trimming flying robot with suspended reciprocating saw
Technical Field
The utility model relates to a hang reciprocating saw's trees pruning flying robot especially relates to a flying robot who is suitable for prune large tracts of land trees fast, belongs to trees trimming means technical field.
Background
At present, three main ways are available for trimming or cleaning trees (particularly high places) in gardens, orchards, driveways, power transmission line channels and the like: 1) the manual trimming operation generally adopts a special or specially-made lengthened trimming cutter, so that the safety risk is high, and the operation efficiency is not high; 2) due to the severe limitation of the terrain environment and the tree growth situation, the branch pruning operation based on ground automatic equipment is difficult to carry out rapid pruning on the overhead trees; 3) the tree pruning technology based on the unmanned aerial vehicle has the defects of weaker tree interference resistance, smaller single pruning range, low operation efficiency and the like.
Therefore, a flying robot capable of automatically trimming gardens, fruit trees, traffic lanes and power transmission line channels in a large range needs to be researched, a reciprocating saw system carried by the flying robot has a large single trimming range, the influence of cutting force on the posture of a flying robot body can be avoided, and safety protection measures such as anti-jamming are provided.
SUMMERY OF THE UTILITY MODEL
The utility model provides a technical problem be: the utility model provides a hang trees pruning flying robot of reciprocating saw carries the reciprocating saw system through rotor class aircraft, realizes large tracts of land, efficient pruning to trees such as gardens, orchard, lane, transmission line passageway, satisfies the high safety of trees pruning operation, high efficiency, the demand of easy-to-use.
The technical scheme of the utility model is that: a tree pruning flying robot for hanging a reciprocating saw comprises a flying platform, a hanging mechanism connected below the flying platform and a reciprocating saw system connected below the hanging mechanism; the suspension mechanism is a connecting rod with fixed length or a telescopic suspension mechanism with variable length, and comprises L (L is more than or equal to 2) vertical rods which are arranged in bilateral symmetry, and a transverse stiffening beam is arranged between the adjacent vertical rods; the reciprocating saw system comprises a cutter frame connected with the suspension mechanism, a cutter motor fixedly connected with the cutter frame, a reciprocating mechanism driven by the cutter motor, a movable saw blade driven by the reciprocating mechanism to move in a reciprocating manner, and a cutter controller driving the cutter motor.
Preferably, a decoupling device for hooking or separating the suspension mechanism and the reciprocating saw system or the flying platform and the suspension mechanism is arranged between the suspension mechanism and the reciprocating saw system.
Preferably, a pitch joint is provided between the suspension mechanism and the flying platform to allow the suspension mechanism and the flying platform to have a degree of freedom of relative pitch motion.
Preferably, the suspension mechanism is a pull-rope type telescopic suspension mechanism, and is characterized in that: the vertical rod comprises H (H is more than or equal to 2) sections of continuously nested hollow pipes, the serial numbers of the H sections are 1, 2, … and H from top to bottom, the upper end of the ith (i is more than or equal to 1 and less than H) section of hollow pipe is provided with an upper stopper for limiting the motion overshoot of the ith +1 section of hollow pipe when the ith section of hollow pipe contracts upwards, and the lower end of the ith section of hollow pipe is provided with a lower stopper for limiting the motion drop of the ith +1 section of hollow pipe when the ith +1 section of hollow pipe extends downwards; the upper stopper of the section 1 hollow tube is provided with a flange connected with the flying platform, the upper end of the section H hollow tube is provided with an upper stopper, the lower end of the section H hollow tube is connected with the reciprocating saw system, and the upper stopper of the section H hollow tube is connected with a wire winding device arranged on the flying platform through a pull rope; the transverse reinforcing beam is connected to the lower ends of the same sections of the hollow tubes of the adjacent vertical rods.
Preferably, the suspension mechanism is a pulley type telescopic suspension mechanism, and is characterized in that: the vertical rod comprises H (H is more than or equal to 3) sections of continuously nested hollow pipes, the serial numbers of the H sections are 1, 2, … and H from top to bottom, the upper end of the ith (i is more than or equal to 1 and less than H) section of hollow pipe is provided with an upper stopper for limiting the motion overshoot of the ith +1 section of hollow pipe when the ith section of hollow pipe contracts upwards, and the lower end of the ith section of hollow pipe is provided with a lower stopper for limiting the motion drop of the ith +1 section of hollow pipe when the ith +1 section of hollow pipe extends downwards; the upper stopper of the 1 st section of hollow tube is provided with a flange connected with the flying platform, the upper end of the H-th section of hollow tube is provided with an upper stopper, the lower end of the H-th section of hollow tube is connected with the reciprocating saw system, and the upper stopper of the 2 nd section of hollow tube is connected with a wire-rewinding device arranged on the flying platform through a pull rope; the vertical rod also comprises a movable pulley, a pulley pull rope and a rotating shaft, wherein the rotating shaft is horizontally fixed on an upper stopper of the j (j < H > is more than or equal to 2) th section of hollow tube, the rotating plane passes through the vertical axis of the hollow tube, the pulley pull rope is hung and wound on the upper side of the movable pulley, one end of the pulley pull rope is fixedly connected with a lower stopper of the j-1 th section of hollow tube, and the other end of the pulley pull rope is fixedly connected with an upper stopper of the j +1 th section of hollow tube; the transverse reinforcing beam is connected to the lower ends of the same sections of the hollow tubes of the adjacent vertical rods.
Preferably, the vertical rod is an electric push rod having a linear telescopic motion function.
Preferably, the wire rewinding device comprises a wire rewinding motor, a wire rewinding disc for rewinding the pull rope, a rotary shifting fork driven to rotate by the wire rewinding motor through a transmission gear, an upper travel switch for sensing that the suspension mechanism ascends to a limit position and a lower travel switch for sensing that the suspension mechanism descends to the limit position, and output signal lines of the upper travel switch and the lower travel switch and a control signal line of the wire rewinding motor are connected with a main controller of the flight platform; and a driving and self-locking relation similar to a worm-worm wheel is formed between the take-up motor and the take-up reel.
Preferably, the reciprocating mechanism comprises an inertia wheel driven by a cutter motor to rotate, a connecting rod connected to the edge of the inertia wheel through a bearing, and a guide motion block which is connected with the other end of the connecting rod through the bearing and can move left and right, the cross section of the guide motion block is wide at the top and narrow at the bottom, and the lower surface of the guide motion block is fixedly connected with a movable saw blade; the inertia wheel, the connecting rod and the guide motion block form a multi-connecting-rod mechanism, and the rotary motion of the cutter motor is converted into the left and right reciprocating motion of the movable saw blade; the lower part of the tool rack is fixedly connected with a fixed saw blade, the fixed saw blade is provided with a groove for accommodating the guide motion block to do left-right reciprocating motion, the outline of the longitudinal section of the groove is wide at the top and narrow at the bottom, and the guide motion block is embedded into the groove to form anti-falling left-right sliding fit; the cutter controller is connected with a main controller of the flying platform through a communication bus; the cutter motor is provided with a current sensor, a rotating speed sensor and a temperature sensor for sensing the current, the rotating speed and the temperature of the cutter motor during working, and output signals of the current sensor, the rotating speed sensor and the temperature sensor are respectively connected to the cutter controller.
Preferably, the unhooking device is a mechanical unhooking device or an electromagnetic unhooking device.
The unhooking device is a mechanical unhooking device and comprises an upper unhooking component and a lower unhooking component which can be mutually hooked with the upper unhooking component; the upper unhooking assembly comprises an upper base, a linear steering engine, an upper hook shaft, an upper hook, a tension spring and an upper electrical interface, wherein the linear steering engine is fixedly connected to the upper base, the output rod of the linear steering engine faces downwards; the lower unhooking component comprises a lower base, a lower hanging buckle which is fixedly connected with the lower base and can form vertical hanging connection with the upper hook, and a lower electric interface which is fixedly connected with the lower base; the upper electrical interface and the lower electrical interface form plug-in connection and are used for transmitting electric energy and control signals; the lower end of the upper hook is a rightward hook, the right lower side of the hook is in an oblique angle shape, and the left upper side of the lower hook buckle is provided with an oblique angle shape which is in extrusion pushing fit with the oblique angle outer contour of the hook of the upper hook; the lower hanging buckle is provided with a square hole matched with the hook of the upper hook, and once the hook of the upper hook is screwed into the square hole, the lower hanging buckle and the upper hook can be reliably hooked; the lower unhooking component also comprises an elastic gasket which is embedded between the lower base and the upper base and is in close contact with the lower base and the upper base; the linear steering engine is connected with a controller in the flight platform, and the linear steering engine drives an output rod of the linear steering engine to extend or contract after receiving an instruction of the controller, so that the upper hook rotates clockwise or anticlockwise in a follow-up mode.
The unhooking device is an electromagnetic unhooking device and comprises an electromagnet and an armature which are fixedly connected with connecting parts at two ends of the unhooking device respectively; the electromagnet is attracted with the armature after being electrified, and the connecting parts at the two ends of the unhooking device are hooked; after the electromagnet is powered off, the armature is released, and the connection parts at the two ends of the unhooking device are separated; the electromagnet is connected with a power supply on the flying robot through a switch. In the obstacle removing operation, when the reciprocating saw system is blocked relative to the branches and cannot be separated, the reciprocating saw system can be separated from the flying robot through the unhooking device, and therefore safety protection is conducted on the flying robot.
Preferably, the flying platform is a multi-rotor aircraft with a bilateral symmetry layout, and is not limited to any fixed known four, six, eight and other multi-rotors.
Preferably, a tilt motor is provided between any pair of rotors of the multi-rotor aircraft and each rotor arm, the tilt motor being capable of rotating the rotors with respect to the axes of the corresponding rotor arms.
Preferably, the pitch joint comprises a pitch joint seat, a pitch joint moving part capable of rotating around a rotating shaft of the pitch joint seat, and a pair of torsion springs which are installed on the rotating shaft of the pitch joint seat and are respectively positioned between the pitch joint moving part and the pitch joint seat; two ends of the torsion spring are respectively fixed on the pitch joint seat and the pitch joint moving part.
Preferably, the flying platform is provided with a forward-looking camera and a downward-looking camera which are used for observing the growth situation of the trees and the cutting state of the reciprocating saw system in a close range.
The working method and the control method of the tree trimming flying robot are as follows:
a working method of a tree obstacle clearing flying robot with a suspended reciprocating saw comprises the following steps:
sequentially connecting the flying platform, the suspension mechanism and the reciprocating saw system from top to bottom to form a flying robot whole; when the flying robot flies to the position near the tree to be trimmed, the length and the flying height of the suspension mechanism are firstly adjusted, the cutter system faces the tree to be trimmed, then the flying robot is controlled to fly forwards according to the received tree trimming remote control command, and the tree below the flying robot is cut and trimmed by the reciprocating saw system.
A control method of a tree obstacle clearing flying robot with a suspended reciprocating saw comprises the following steps:
the control method comprises a control method of a suspension mechanism, a control method of a reciprocating saw system and a control method of a unhooking device, and specifically comprises the following steps:
1) the control method of the suspension mechanism adopting the telescopic structure comprises the following steps: the main controller of the flight platform dynamically changes the length of the stay cord by controlling the starting and stopping of the wire rewinding device and the wire rewinding and releasing direction, so that the length of the vertical rod is adjusted, and the vertical distance of the reciprocating saw system relative to the flight platform is changed.
2) The control method of the reciprocating saw system comprises the following steps:
A) the cutter controller collects the current, the rotating speed and the temperature of the cutter motor in real time when the cutter motor works and sends the current, the rotating speed and the temperature to the main controller of the flying platform for monitoring;
B) evaluating the working state of the reciprocating saw in real time:
firstly, setting a current threshold, a rotating speed threshold and a temperature threshold corresponding to overload to be known, and if the current of a cutter motor exceeds the current threshold, or the rotating speed is lower than the rotating speed threshold, or the temperature exceeds the temperature threshold, judging that the reciprocating saw is overloaded;
secondly, setting a current threshold, a rotating speed threshold and a temperature threshold corresponding to the blockage to be known, and if the current of the cutter motor exceeds the current threshold, or the rotating speed is lower than the rotating speed threshold, or the temperature exceeds the temperature threshold, judging that the reciprocating saw is blocked;
and thirdly, if the current or the rotating speed of the cutter motor has periodic pulsation and the amplitude exceeds a preset threshold, the reciprocating saw can be judged to be damaged.
C) The method for processing the exception of the working state comprises the following steps:
if the flying platform is judged to be overloaded, a hovering instruction is sent to the flying platform, and cutting feeding is stopped;
if the tool is judged to be blocked or damaged, the motor of the tool is braked, and a backspacing instruction is sent to the flying platform;
and thirdly, for the jamming, if the reciprocating saw is clamped by the branches and is difficult to break loose, the unhooking device is started to enable the reciprocating saw system to break away from the flying robot, so that the safety of the flying robot is protected to the maximum extent, and the crash is avoided.
3) The control method of the mechanical unhooking device comprises the following steps:
A) when the unhooking device receives an unhooking command of a main controller in the flight platform, an output rod of the linear steering engine extends to drive the bearing to move downwards, the bearing is in pressing contact with an upper plane of a transverse rod of the upper hook to push the upper hook to rotate clockwise, and a hook at the lower end of the upper hook is separated from the lower hook buckle, so that mechanical unhooking of a part connected below the unhooking device and a part connected above the unhooking device is realized, and meanwhile, separation of an electrical interface is also completed; then, an output rod of the linear steering engine contracts, and the upper hook rotates anticlockwise to reset under the action of the tension spring;
B) when the lower hanging buckle moves upwards to extrude the hook of the upper hook leftwards, the upper hook is pushed to rotate clockwise to give way, and when the lower hanging buckle moves upwards to a proper position, the hook of the upper hook is quickly screwed into the square hole of the lower hanging buckle, so that a part connected below the unhooking device and a part connected above the unhooking device are stably and reliably hooked, and meanwhile, the connection of an electrical interface is also completed.
The utility model has the advantages that: compared with the prior art, the utility model discloses an effect as follows:
1) the utility model adopts the flight platform to hang the reciprocating saw system, is suitable for carrying out 'shaving head type' large-area rapid trimming from the top or the side of the tree, has high operation efficiency, avoids the operator to be close to the trimmed tree and the dangerous equipment around the trimmed tree, can effectively reduce the operation risk of tree trimming, and solves the problems of low cleaning efficiency and large safety risk existing in the prior art;
2) the flying robot with the reciprocating saw system is suspended, and the reciprocating saw system is always positioned below the rotor wing assembly during operation, so that the interference of trees on the rotor wings can be effectively avoided, the risk of falling is reduced, and the operation safety of the flying robot is improved;
3) the suspension mechanism has various configurations such as fixing, stretching and the like, and meets the diversity of the operating environment; particularly, the distance between the reciprocating saw system and the flying platform can be dynamically adjusted due to the telescopic configuration of the vertical rod, so that the flying robot is more flexible and mobile to use, can effectively reduce the taking-off and landing difficulty of the flying robot, and is easy to store and transport;
4) the suspension mechanism and the reciprocating saw system are positioned below the flying platform, so that the center of gravity of the flying robot is positioned right below the flying platform, the stability of the flying robot is improved, and the control difficulty of the flying robot is reduced;
5) the suspension mechanism adopts a left-right bilateral symmetry structure and is fixedly connected below the flying platform, and meanwhile, the transverse stiffening beam is additionally arranged on the vertical rod, so that the flying robot has stronger rigidity as a whole, and the stability and reliability of system operation are improved. When the suspension operation device is subjected to external force, compared with a single vertical rod mode, the course of the reciprocating saw system is not easy to twist relative to the flying platform, the deformation or fracture of the suspension mechanism is difficult to cause, and the operation safety of the flying robot is ensured;
6) the reciprocating saw is transversely arranged along the length direction, has larger transverse operation width, large one-time operation range, high cutting efficiency and good applicability;
7) the cutter motor is provided with a sensor for sensing the working current, the rotating speed and the temperature of the cutter motor, and the control system analyzes and processes sensor data and implements protective retreat control on the flying robot, so that the safety of the flying robot in operation is ensured;
8) the reciprocating saw system has various shapes and tooth shapes, and can meet the tree trimming requirements under different operation targets and operation environments by combining the motion planning of the robot, so that the reciprocating saw system is convenient and reliable;
9) when the reciprocating saw system is wound by branches and leaves and cannot break loose, the unhooking device can be manually or automatically started, so that the reciprocating saw system and the suspension mechanism or the suspension mechanism and the flight platform can be quickly separated, the safety of the flight robot is guaranteed, and the loss caused by faults is reduced.
Drawings
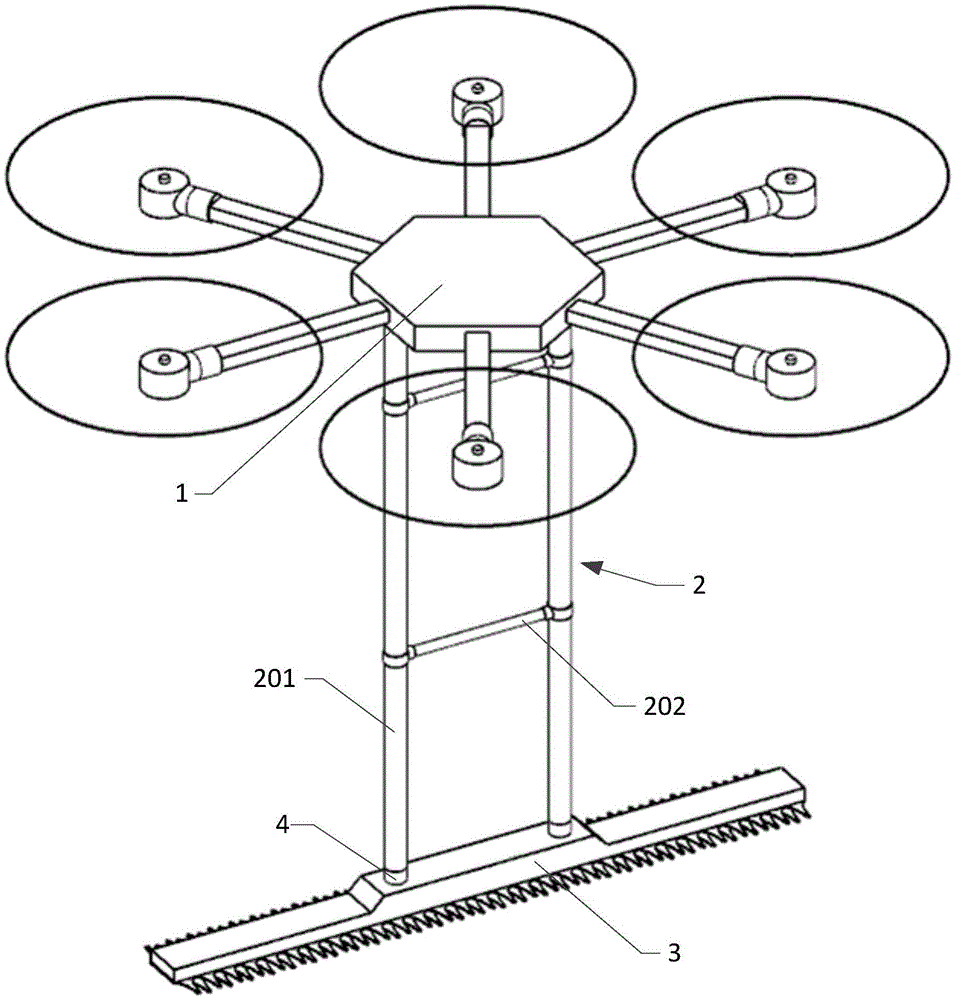
FIG. 1 is a schematic view of a flying robot suspending a linear reciprocating saw system;
FIG. 2 is a schematic view of the internal structure of the vertical rod of the pull-rope type suspension mechanism;
FIG. 3 is a schematic view of the suspension mechanism in an extended and retracted state with respect to the vertical rods;
FIG. 4 is a schematic view of a wire rewinding device;
FIG. 5 is a schematic view of the reciprocating saw system;
FIG. 6 is a schematic view of the internal structure of the linear reciprocating saw system;
FIG. 7 is a schematic view of a portion of a linear reciprocating saw system;
FIG. 8 is a schematic view of the reciprocating mechanism of the linear reciprocating saw system;
FIG. 9 is a side cross-sectional schematic view of the linear reciprocating saw system;
fig. 10 is a schematic view of a separated state of the mechanical unhooking device;
fig. 11 is a schematic view showing a hitching state of the mechanical unhooking device;
FIG. 12 is a schematic view showing the internal structure of a vertical rod of the pulley type suspension mechanism;
FIG. 13 is a schematic structural view of an electromagnetic type unhooking device;
figure 14 is a schematic view of a tiltrotor configuration;
FIG. 15 is a schematic view of a pitch joint structure;
FIG. 16 is a schematic view of a circular arc reciprocating saw system;
FIG. 17 is a schematic view of a flying robot suspending a circular arc reciprocating saw system.
In the figure, 1 is a flying platform, 2 is a suspension mechanism, 3 is a reciprocating saw system, 4 is a unhooking device, and 5 is a pitching joint;
1011-rotor, 1012-rotor arm, 1013-tilting motor;
201-vertical pole, 202-transverse stiffening beam;
2201-wire taking-up device, 2202-pulling rope, 2203-hollow tube, 2204-upper limiter, 2205-lower limiter, 2206-movable pulley, 2207-pulley pulling rope and 2208-flange;
22011-a wire take-up motor, 22012-a wire take-up reel, 22013-a transmission gear, 22014-a rotary shifting fork, 22015-an upper travel switch and 22016-a lower travel switch;
301-tool holder, 302-tool motor, 303-flywheel, 304-connecting rod, 305-guiding motion block, 306-movable saw blade, 307-fixed saw blade;
41-upper unhooking component, 4101-upper base, 4102-linear steering engine, 4103-bearing, 4104-tension spring, 4105-upper hook, 4106-upper hook shaft and 4107-upper electrical interface;
42-lower unhooking assembly, 4201-lower base, 4202-lower hook, 4203-lower electrical interface, 4204-resilient washer;
401-electromagnet, 402-armature;
501-pitching joint base, 502-pitching joint movable piece and 503-torsion spring.
Detailed Description
The present invention will be further described with reference to the accompanying drawings and specific embodiments.
Example 1: as shown in fig. 1 to 11, a tree pruning flying robot with a suspended reciprocating saw comprises a flying platform 1, a suspension mechanism 2 connected below the flying platform 1 and a reciprocating saw system 3 connected below the suspension mechanism 2; the suspension mechanism 2 is a connecting rod with fixed length or a telescopic suspension mechanism with variable length, and comprises L (L is more than or equal to 2) vertical rods 201 which are arranged in bilateral symmetry, and a transverse reinforcing beam 202 is arranged between the adjacent vertical rods 201; the reciprocating saw system 3 comprises a tool frame 301 connected with the suspension mechanism 2, a tool motor 302 fixedly connected with the tool frame 301, a reciprocating mechanism driven by the tool motor 302, a movable saw blade 306 driven by the reciprocating mechanism to reciprocate, and a tool controller driving the tool motor 302.
Preferably, a unhooking device 4 capable of hooking and detaching the suspension mechanism 2 and the reciprocating saw system 3 or the flying platform 1 and the suspension mechanism 2 is arranged between the suspension mechanism 2 and the reciprocating saw system.
Preferably, the suspension mechanism 2 is a pull rope type telescopic suspension mechanism structure: the vertical rod 201 comprises H (H is more than or equal to 2) sections of continuously nested hollow tubes 2203, the serial numbers of the H sections are 1, 2, … and H from top to bottom, the upper end of the ith (i is more than or equal to 1 and less than H) section of hollow tube 2203 is provided with an upper stopper 2204 for limiting the motion overshoot of the ith +1 section of hollow tube 2203 when the ith section of hollow tube 2203 contracts upwards, and the lower end of the ith (i + 1) section of hollow tube 2203 is provided with a lower stopper 2205 for limiting the motion drop of the ith +1 section of hollow tube 2203 when the ith +1 section of hollow tube 2203 extends downwards; the upper stopper 2204 of the 1 st section of hollow tube 2203 is provided with a flange 2208 connected with the flying platform 1, the upper end of the H-th section of hollow tube 2203 is provided with the upper stopper 2204, and the lower end is connected with the reciprocating saw system 3; an upper limiter 2204 of the H-th section of hollow tube 2203 is connected with a wire rewinding device 2201 arranged on the flying platform 1 through a pull rope 2202; the transverse reinforcement beam 202 is connected to the lower end of the same section of hollow tube 2203 of the adjacent vertical rod 201.
If the wire rewinding device 2201 winds the pulling rope 2202, the upper limiter 2204 of the H-section hollow tube 2203 is pulled upwards, when the upper limiter 2204 moves upwards to contact the upper limiter 2204 of the H-1 section hollow tube 2203, the H-1 section hollow tube 2203 is driven to move upwards, and by analogy, the H-2 sections of continuously nested hollow tubes 2203 move upwards in sequence, and the vertical rod 201 contracts; if the wire rewinding device 2201 releases the pulling rope 2202, the H-2 sections of the hollow tubes 2203 move downwards in sequence under the action of gravity and the limiting action of the lower limiters 2205 of the sections of the hollow tubes 2203, so that the vertical rod 201 is extended.
Preferably, the wire rewinding device 2201 comprises a wire rewinding motor 22011, a wire rewinding disc 22012 for rewinding a pulling rope 2202, a rotary shifting fork 22014 driven by the wire rewinding motor 22011 to rotate through a transmission gear 22013, an upper travel switch 22015 for sensing that the suspension mechanism 2 ascends to a limit position, and a lower travel switch 22016 for sensing that the suspension mechanism 2 descends to a limit position, wherein output signal lines of the upper travel switch 22015 and the lower travel switch 22016, and a control signal line of the wire rewinding motor 22011 are both connected with a main controller of the flight platform 1; the wire take-up motor 22011 and the wire take-up reel 22012 form a driving and self-locking relationship similar to a worm-worm wheel.
Preferably, the reciprocating mechanism comprises an inertia wheel 303 driven by a cutter motor 302 to rotate, a connecting rod 304 connected to the edge of the inertia wheel 303 through a bearing, and a guide motion block 305 connected with the other end of the connecting rod 304 through the bearing and capable of moving left and right, wherein the cross section of the guide motion block 305 is wide at the top and narrow at the bottom, and a movable saw blade 306 is fixedly connected to the lower surface of the guide motion block; the inertia wheel 303, the connecting rod 304 and the guide motion block 305 form a multi-connecting-rod mechanism, and the rotary motion of the cutter motor 302 is converted into the left and right reciprocating motion of the movable saw blade 306; a fixed saw blade 307 is fixedly connected to the lower part of the tool rest 301, a groove for accommodating the guide motion block 305 to reciprocate left and right is formed in the fixed saw blade 307, the outline of the longitudinal section of the groove is wide at the top and narrow at the bottom, and the guide motion block 305 is embedded into the groove to form anti-falling left and right sliding fit; the cutter controller is connected with a main controller of the flying platform 1 through a communication bus; the cutter motor 302 is provided with a current sensor, a rotating speed sensor and a temperature sensor which respectively sense the current, the rotating speed and the temperature when the cutter motor works, and output signals of the current sensor, the rotating speed sensor and the temperature sensor are respectively connected to the cutter controller.
Preferably, the unhooking device 4 is a mechanical unhooking device, and comprises an upper unhooking component 41 and a lower unhooking component 42 which can be mutually hooked with the upper unhooking component 41; the upper unhooking component 41 comprises an upper base 4101, a linear steering engine 4102 which is fixedly connected with the upper base 4101 and the output rod of which is downward, an upper hook shaft 4106 which is fixedly connected with the upper base 4101, an upper hook 4105 which takes the shape of L with the upper hook shaft 4106 as a rotating shaft, a tension spring 4104 which is arranged between the tail ends of the transverse rods of the upper base 4101 and the upper hook 4105 and can provide anticlockwise restoring moment for the upper hook 4105, and an upper electrical interface 4107 which is fixedly connected with the upper base 4101, wherein the tail end of the output rod of the linear steering engine 4102 is provided with a bearing 4103; the lower unhooking assembly 42 comprises a lower base 4201, a lower hook 4202 fixed to the lower base 4201 and capable of being hooked up and down with the upper hook 4105, and a lower electrical interface 4203 fixed to the lower base 4201; upper electrical interface 4107 forms a mating connection with lower electrical interface 4203 for transferring power and control signals; the lower end of the upper hook 4105 is a rightward hook, the right lower side of the hook is in an oblique angle shape, and the left upper side of the lower hanging buckle 4202 is provided with an oblique angle shape which is matched with the oblique angle outer contour of the hook of the upper hook 4105 in an extrusion and pushing manner; the lower buckle 4202 is provided with a square hole for matching with the hook of the upper hook 4105, and once the hook of the upper hook 4105 is screwed into the square hole, the lower buckle 4202 and the upper hook 4105 can form a reliable hook connection; the lower unhooking element 42 further comprises an elastic washer 4204 embedded between and in close contact with the lower base 4201 and the upper base 4101; the linear steering engine 4102 is connected with a main controller in the flight platform 1, and the linear steering engine 4102 drives an output rod of the linear steering engine to extend or contract after receiving an instruction of the main controller, so that the upper hook 4105 is driven to rotate clockwise or anticlockwise in a follow-up manner.
Preferably, the flying platform 1 is a multi-rotor aircraft with a bilateral symmetry layout, and is not limited to any fixed known four, six, eight and other multi-rotors.
Preferably, the flying platform 1 is provided with a front-view camera and a lower-view camera for closely observing the growth situation of the trees and the cutting state of the reciprocating saw system 3.
The utility model relates to a work method and the control method of hanging trees pruning flying robot of reciprocating saw system as follows:
a working method of a tree obstacle clearing flying robot with a suspended reciprocating saw comprises the following steps:
sequentially connecting the flying platform 1, the suspension mechanism 2 and the reciprocating saw system 3 from top to bottom to form a flying robot whole; when the flying robot flies to the position near the tree to be trimmed, the length and the flying height of the suspension mechanism 2 are firstly adjusted, the cutter system 3 faces the tree to be trimmed, then the flying robot is controlled to fly forwards according to the received tree trimming remote control command, and the tree below the flying robot is cut and trimmed by the reciprocating saw system 3.
A control method of a tree obstacle clearing flying robot with a suspended reciprocating saw comprises the following steps:
1) the control method of the suspension mechanism 2 adopting the telescopic structure comprises the following steps: the main controller of the flying platform 1 dynamically changes the length of the pull rope 2202 by controlling the start/stop and the wire take-up and pay-off directions of the wire take-up 2201, thereby adjusting the length of the vertical rod 201 and changing the vertical distance of the reciprocating saw system 3 relative to the flying platform 1.
2) The control method of the reciprocating saw system 3 is as follows:
A) the cutter controller collects the current, the rotating speed and the temperature of the cutter motor 302 during working in real time and sends the current, the rotating speed and the temperature to the main controller of the flying platform 1 for monitoring;
B) the working state of the reciprocating saw 306 is evaluated in real time:
firstly, setting a current threshold, a rotating speed threshold and a temperature threshold corresponding to overload to be known, and if the current of the cutter motor 302 exceeds the current threshold, or the rotating speed is lower than the rotating speed threshold, or the temperature exceeds the temperature threshold, judging that the reciprocating saw 306 is overloaded;
secondly, setting a current threshold, a rotating speed threshold and a temperature threshold corresponding to the blockage to be known, and if the current of the cutter motor 302 exceeds the current threshold, or the rotating speed is lower than the rotating speed threshold, or the temperature exceeds the temperature threshold, judging that the reciprocating saw 306 is blocked;
thirdly, if the current or the rotating speed of the cutter motor 302 has periodic pulsation and the amplitude exceeds a preset threshold, the reciprocating saw 306 can be judged to be damaged.
C) The method for processing the exception of the working state comprises the following steps:
if the flying platform is judged to be overloaded, a hovering instruction is sent to the flying platform 1, and cutting feeding is stopped;
if the tool is determined to be blocked or damaged, the tool motor 302 is braked, and a backspacing instruction is sent to the flying platform 1;
for the jamming, if the reciprocating saw 306 is clamped by the branches and is difficult to break loose, the unhooking device 4 is started to enable the reciprocating saw system 3 to break away from the flying robot, so that the safety of the flying robot is protected to the maximum extent, and the crash is avoided.
3) Control method of mechanical unhooking device 4:
A) when the unhooking device 4 receives an unhooking command of a main controller in the flight platform 1, an output rod of the linear steering engine 4102 extends to drive the bearing 4103 to move downwards, the bearing 4103 is in pressing contact with an upper plane of a transverse rod of the upper hook 4105 to push the upper hook 4105 to rotate clockwise, and a hook at the lower end of the upper hook 4105 is separated from the lower hanging buckle 4202, so that mechanical unhooking of a part connected below the unhooking device 4 and a part connected above the unhooking device 4 is realized, and meanwhile, separation of an electrical interface is also completed; then, the output rod of the linear steering engine 4102 is contracted, and the upper hook 4105 rotates anticlockwise to reset under the action of the tension spring 4104;
B) when hooking, the lower hook 4202 moves upward to press the hook of the upper hook 4105 leftward, pushing the upper hook 4105 to rotate clockwise to give way, and when the lower hook 4202 moves upward to a proper position, the hook of the upper hook 4105 is quickly screwed into the square hole of the lower hook 4202, thereby forming a stable and reliable hook between the component connected below the unhooking device 4 and the component connected above the unhooking device 4, and completing the connection of the electrical interface.
Example 2: as shown in fig. 12, a tree pruning flying robot for hanging a reciprocating saw, the hanging mechanism 2 adopts a pulley type telescopic hanging mechanism: the vertical rod 201 comprises H (H is more than or equal to 3) sections of continuously nested hollow tubes 2203, the serial numbers of the H sections are 1, 2, … and H from top to bottom, the upper end of the ith (i is more than or equal to 1 and less than H) section of hollow tube 2203 is provided with an upper stopper 2204 for limiting the motion overshoot of the ith +1 section of hollow tube 2203 when the ith section of hollow tube 2203 contracts upwards, and the lower end of the ith (i + 1) section of hollow tube 2203 is provided with a lower stopper 2205 for limiting the motion drop of the ith +1 section of hollow tube 2203 when the ith +1 section of hollow tube 2203 extends downwards; an upper stopper 2204 of the 1 st section of hollow tube 2203 is provided with a flange 2208 connected with the flying platform 1, the upper end of the H-th section of hollow tube 2203 is provided with an upper stopper 2204, the lower end of the H-th section of hollow tube 2203 is connected with the reciprocating saw system 3, and the upper stopper 2204 of the 2 nd section of hollow tube 2203 is connected with a wire-rewinding device 2201 arranged on the flying platform 1 through a pull rope 2202; when the number of the sections H of the hollow tube 2203 is more than or equal to 3, the vertical rod 201 further comprises a movable pulley 2206, a rotating shaft of which is horizontally fixed on an upper stopper 2204 of the j (2 is more than or equal to j < H) th section of the hollow tube 2203 and a rotating plane of which passes through the vertical axis of the hollow tube 2203, and a pulley pull rope 2207, one end of which is hung on the upper side of the movable pulley 2206 and is fixedly connected with a lower stopper 2205 of the j-1 th section of the hollow tube 2203, and the other end of which is fixedly connected with an upper stopper 2204 of the j +1 th section of the hollow tube 2203; the transverse reinforcement beam 202 is connected to the lower end of the same section of hollow tube 2203 of the adjacent vertical rod 201.
The suspension mechanism 2 is raised: a main controller of the flying platform 1 outputs a forward rotation instruction to a wire take-up motor 22011, the wire take-up motor 22011 drives a wire take-up disc 22012 to take up a pulling rope 2202 and enable a rotary shifting fork 22014 to rotate forward, the pulling rope 2202 rises to drive a 2 nd section of hollow tube 2203 of the vertical rod 201 to move upwards and a movable pulley 2206 on the section of hollow tube 2203 to move upwards, a pulley pulling rope 2207 which bypasses the movable pulley 2206 is driven to drive a 3 rd section of hollow tube 2203 to move upwards synchronously, and the rest is done in the same way, and the N section of hollow tube 2203 is driven to move upwards synchronously; when all the vertical rods 201 synchronously act according to the method, the suspension mechanism 2 is stably lifted; when the suspension mechanism 2 ascends to the limit position, the rotary shifting fork 22014 triggers the upper travel switch 22015, the main controller of the flight platform 1 outputs a stalling instruction to the wire take-up motor 22011, the wire take-up motor 22011 stalls, and therefore the suspension mechanism 2 is protected from ascending.
The suspension mechanism 2 descends: the main controller of the flying platform 1 outputs a reverse rotation instruction to a wire take-up motor 22011, the wire take-up motor 22011 drives a wire take-up reel 22012 to release a pull rope 2202 and enable a rotary shifting fork 22014 to rotate reversely, under the action of a movable hollow tube 2203 of the vertical rod 201 and a load force below the movable hollow tube 2203, the 2 nd section of hollow tube 2203 moves downwards, a movable pulley 2206 on the section of hollow tube 2203 moves downwards, a pulley pull rope 2207 which bypasses the movable pulley 2206 is enabled to drive the 3 rd section of hollow tube 2203 to synchronously move downwards, and the rest is done in the same way, the N section of hollow tube 2203 is driven to synchronously move downwards all the time; when all the vertical rods 201 synchronously act according to the method, the suspension mechanism 2 is stably descended; when the suspension mechanism 2 descends to the limit position, the rotary fork 22014 triggers the lower travel switch 22016, the main controller of the flight platform 1 outputs a stalling instruction to the wire take-up motor 22011, the wire take-up motor 22011 stalls, and therefore the suspension mechanism 2 is protected from descending.
Example 3: a tree pruning flying robot for hanging a reciprocating saw is characterized in that a vertical rod 201 of a hanging mechanism 2 in embodiment 1 is an electric push rod with a linear motion function.
Example 4: a tree pruning flying robot for hanging a reciprocating saw is characterized in that a unhooking device 4 is electromagnetic and comprises an electromagnet 401 and an armature 402 which are fixedly connected with connecting parts at two ends of the unhooking device 4 respectively; the electromagnet 401 is connected with a power supply on the flying robot through a switch.
As shown in fig. 13, the electromagnet 401 is electrified and then attracted with the armature 402, and the reciprocating saw system 3 is hung below the suspension mechanism 2; when the electromagnet 401 is de-energized, the armature 402 is released and the reciprocating saw system 3 is separated from the suspension mechanism 2. In the obstacle clearing operation, when the reciprocating saw system 3 is blocked relative to branches and cannot be separated, the reciprocating saw system 3 can be separated from the flying robot through the unhooking device 4, and therefore safety protection is conducted on the flying robot.
Example 5: as shown in fig. 14, a tree pruning flying robot with a suspended reciprocating saw is provided with a tilt motor 1013 capable of rotating a pair of rotors 1011 between each of a pair of rotors 1011 and each of rotor arms 1012 of a multi-rotor aircraft, thereby realizing tilt rotors.
Based on the tilt rotor, the flying platform 1 can generate a large course moment to overcome the unbalanced reaction moment of the trees received by the reciprocating saw system 3, and can realize horizontal flight on the premise of not changing the posture.
Example 6: as shown in figure 15, a tree pruning flying robot for suspending a reciprocating saw is characterized in that a pitching joint 5 which can enable the suspension mechanism 2 and a flying platform 1 to have relative pitching motion freedom degree is arranged between the suspension mechanism 2 and the flying platform 1.
Preferably, the pitch joint 5 comprises a pitch joint seat 501, a pitch joint moving member 502 capable of rotating around a rotating shaft of the pitch joint seat 501, and a pair of torsion springs 503 which are installed on the rotating shaft of the pitch joint seat 501 and are respectively located between the pitch joint moving member 502 and the pitch joint seat 501; both ends of the torsion spring 503 are fixed to the pitch joint base 501 and the pitch joint movable piece 502, respectively.
Example 7: as shown in fig. 16 and 17, a tree pruning flying robot with a reciprocating saw suspended thereon, the reciprocating saw system 3 is a circular arc reciprocating saw system, and the tree can be pruned into various appearance shapes by matching with the motion track of the flying robot, such as:
1) if the flying robot moves back and forth in a straight line, the trees can be trimmed to be arc-shaped;
2) if the flying robot rotates at a fixed point, the trees can be trimmed to be in a hemispherical appearance;
3) if the flying robot moves horizontally and rotates, the tree can be trimmed into a spiral arc shape;
4) if the flying robot moves horizontally, vertically and rotationally, the tree can be trimmed to be in a more complicated appearance shape.
Example 8: a flying robot for pruning trees by hanging a reciprocating saw is characterized in that when a fixed saw blade of a reciprocating saw system 3 has no saw teeth, the reciprocating saw system based on a single-layer saw blade is obtained.
The above description is only an example of the specific embodiments of the present invention, and the scope of the present invention is not limited thereto. Those skilled in the art can easily find changes or substitutions within the technical scope of the present invention, which is covered by the protection scope of the present invention. For this reason, the protection scope of the present invention shall be subject to the protection scope of the claims.