CN212527764U - Novel ribbon stacking robot - Google Patents
Novel ribbon stacking robot Download PDFInfo
- Publication number
- CN212527764U CN212527764U CN202021252748.8U CN202021252748U CN212527764U CN 212527764 U CN212527764 U CN 212527764U CN 202021252748 U CN202021252748 U CN 202021252748U CN 212527764 U CN212527764 U CN 212527764U
- Authority
- CN
- China
- Prior art keywords
- crossbeam
- drive arrangement
- fixedly connected
- motor
- supporting leg
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
- 235000017166 Bambusa arundinacea Nutrition 0.000 description 2
- 235000017491 Bambusa tulda Nutrition 0.000 description 2
- 241001330002 Bambuseae Species 0.000 description 2
- 235000015334 Phyllostachys viridis Nutrition 0.000 description 2
- 239000011425 bamboo Substances 0.000 description 2
- 230000004048 modification Effects 0.000 description 2
- 238000012986 modification Methods 0.000 description 2
- 230000009286 beneficial effect Effects 0.000 description 1
- 238000004804 winding Methods 0.000 description 1
Images

Landscapes
- Manipulator (AREA)
Abstract
The utility model belongs to the technical field of pile up neatly machine people, especially be a novel ribbon pile up neatly machine people, including the supporting leg, the quantity of supporting leg is four, two the top fixedly connected with first crossbeam of supporting leg, another two the top fixedly connected with another first crossbeam of supporting leg, two the top of first crossbeam all is provided with first drive arrangement, the top fixedly connected with same second crossbeam of two first drive arrangements, the top of second crossbeam is provided with the second drive arrangement, the side fixedly connected with electric putter of second drive arrangement; the utility model discloses, through setting up first crossbeam, second crossbeam, first drive arrangement and second drive arrangement to cooperation electric putter, clamping jaw and electronic hydraulic rod can be convenient for press from both sides the reel and get, and through first drive arrangement and second drive arrangement, be convenient for transport the pile up neatly to banded goods, improve work efficiency.
Description
Technical Field
The utility model belongs to the technical field of the pile up neatly machine people, concretely relates to novel ribbon pile up neatly machine people.
Background
In the industry, the ribbon goods has a great variety, and the ribbon goods is in the production back, generally can be through mechanical device with the surface of ribbon goods winding at the reel to in transit and deposit, because the reel is cylindric greatly, lead to after the ribbon goods is convoluteed, the workman can not be fast convenient carry out the pile up neatly with it, have certain inconvenience, and current pile up neatly device can not be applicable to the pile up neatly to the reel.
SUMMERY OF THE UTILITY MODEL
To solve the problems set forth in the background art described above. The utility model provides a novel ribbon pile up neatly machine people has the pile up neatly of being convenient for, characteristics simple to use.
In order to achieve the above object, the utility model provides a following technical scheme: the utility model provides a novel ribbon pile up neatly machine people, includes the supporting leg, the quantity of supporting leg is four, two the first crossbeam of top fixedly connected with of supporting leg, another two another first crossbeam of top fixedly connected with of supporting leg, two the top of first crossbeam all is provided with first drive arrangement, two the same second crossbeam of first drive arrangement's top fixedly connected with, the top of second crossbeam is provided with second drive arrangement, second drive arrangement's side fixedly connected with electric putter, electric putter's bottom is provided with the backup pad, the equal swing joint in bottom both ends of backup pad has the clamping jaw, the side of supporting leg is provided with the controller.
Preferably, the first driving device comprises a first fixing plate, a first bearing wheel is movably connected to the side face of the first fixing plate, the first bearing wheel is connected to the top of the first cross beam in a lap joint mode, a first rack is arranged on the side face of the first cross beam, a first motor is arranged on the side face of the first fixing plate, a first gear is arranged on the surface of an output shaft of the first motor, the first gear is meshed with the first rack, and the first driving device is fixedly connected to the top of the first fixing plate and two ends of the bottom of the second cross beam.
Preferably, the second driving device comprises a second fixing plate, a second bearing wheel is movably connected to the side face of the second fixing plate, the second bearing wheel is connected to the top of the second cross beam in a lap joint mode, a second motor is arranged on the side face of the second fixing plate, a second gear is arranged on the surface of an output shaft of the second motor, a second rack is arranged on the side face of the second cross beam, the second gear is meshed with the second rack, and electric push rods are fixedly connected to the two sides of the second fixing plate.
Preferably, the controller is electrically connected with the first motor, the second motor and the electric push rod through wires respectively.
Preferably, the two ends of the top of the first cross beam and the two ends of the top of the second cross beam are both provided with limiting blocks.
Preferably, the opposite surfaces of the two clamping jaws are movably connected with an electric hydraulic push rod, and the electric hydraulic push rod is electrically connected with the controller through a lead.
Compared with the prior art, the beneficial effects of the utility model are that:
the utility model discloses, through setting up first crossbeam, second crossbeam, first drive arrangement and second drive arrangement to cooperation electric putter, clamping jaw and electronic hydraulic rod can be convenient for press from both sides the reel and get, and through first drive arrangement and second drive arrangement, be convenient for transport the pile up neatly to banded goods, improve work efficiency.
Drawings
The accompanying drawings are included to provide a further understanding of the invention, and are incorporated in and constitute a part of this specification, illustrate embodiments of the invention, and together with the description serve to explain the invention and not to limit the invention. In the drawings:
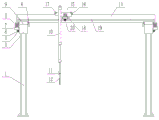
fig. 1 is a schematic front view of the present invention;
FIG. 2 is a schematic side view of the present invention;
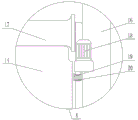
FIG. 3 is an enlarged schematic structural view of the position A of the present invention;
in the figure: 1. supporting legs; 2. a controller; 3. a first cross member; 4. a first rack; 5. a first driving device; 6. a first fixing plate; 7. a first motor; 8. a first gear; 9. a first load-bearing wheel; 10. an electric push rod; 11. a support plate; 12. a clamping jaw; 13. an electric hydraulic push rod; 14. a second cross member; 15. a second driving device; 16. a second fixing plate; 17. a second bearing wheel; 18. a second motor; 19. a second rack; 20. a second gear.
Detailed Description
The technical solutions in the embodiments of the present invention will be described clearly and completely with reference to the accompanying drawings in the embodiments of the present invention, and it is obvious that the described embodiments are only some embodiments of the present invention, not all embodiments. Based on the embodiments in the present invention, all other embodiments obtained by a person skilled in the art without creative work belong to the protection scope of the present invention.
Examples
Referring to fig. 1-3, the present invention provides the following technical solutions: a novel belt stacking robot comprises supporting legs 1, wherein the number of the supporting legs 1 is four, the top ends of two supporting legs 1 are fixedly connected with a first cross beam 3, the top ends of the other two supporting legs 1 are fixedly connected with another first cross beam 3, the top parts of the two first cross beams 3 are respectively provided with a first driving device 5, the top parts of the two first driving devices 5 are fixedly connected with the same second cross beam 14, the top part of the second cross beam 14 is provided with a second driving device 15, the side surface of the second driving device 15 is fixedly connected with an electric push rod 10, the bottom end of the electric push rod 10 is provided with a supporting plate 11, the two ends of the bottom part of the supporting plate 11 are respectively and movably connected with a clamping jaw 12, the side surface of each supporting leg 1 is provided with a controller 2, and through the arrangement of the first cross beams 3, the second cross beams 14, the first driving devices 5 and the second, and cooperation electric putter 10, clamping jaw 12 and electronic hydraulic rod 13 can be convenient for press from both sides the reel and get to through first drive arrangement 5 and second drive arrangement 15, be convenient for transport the pile up neatly to banded goods, improve work efficiency.
Specifically, first drive arrangement 5 includes first fixed plate 6, the side swing joint of first fixed plate 6 has first bearing wheel 9, first bearing wheel 9 overlap joint is at the top of first crossbeam 3, the side of first crossbeam 3 is provided with first rack 4, the side of first fixed plate 6 is provided with first motor 7, the output shaft surface of first motor 7 is provided with first gear 8, first gear 8 and first rack 4 intermeshing, two the bottom both ends fixed connection of first fixed plate 6 top and second crossbeam 14 of first drive arrangement 5.
Specifically, the second driving device 15 includes a second fixing plate 16, a second bearing wheel 17 is movably connected to a side surface of the second fixing plate 16, the second bearing wheel 17 is overlapped on the top of the second cross beam 14, a second motor 18 is arranged on a side surface of the second fixing plate 16, a second gear 20 is arranged on the surface of an output shaft of the second motor 18, a second rack 19 is arranged on a side surface of the second cross beam 14, the second gear 20 and the second rack 19 are meshed with each other, and electric push rods 10 are fixedly connected to two sides of the second fixing plate 16.
Specifically, the controller 2 is electrically connected to the first motor 7, the second motor 18 and the electric push rod 10 through wires.
Specifically, the two ends of the top of the first beam 3 and the two ends of the top of the second beam 14 are both provided with limiting blocks.
Specifically, the opposite surfaces of the two clamping jaws 12 are movably connected with an electric hydraulic push rod 13, and the electric hydraulic push rod 13 is electrically connected with the controller 2 through a lead.
The utility model discloses a theory of operation and use flow: the utility model discloses, during the use, switch on external power supply with controller 2, when the reel that needs the pile up neatly to twine the banding goods, move through controller 2 control first drive arrangement 5 and second drive arrangement 15, thereby make clamping jaw 12 move to the top of reel, then control electric putter 10 through controller 2 and stretch out, make clamping jaw 12 stretch into the hollow section of thick bamboo of reel, then control electric hydraulic push rod 13 through controller 2 and extend, promote clamping jaw 12 and expand, make the outside of clamping jaw 12 block the hollow section of thick bamboo inner wall, then control first drive arrangement 5 and second drive arrangement 15 through controller 2 and move, drive the reel and move, and control the height of reel through the shrink volume control electric putter 10, when moving to the pile up neatly position, control electric hydraulic push rod 13 through controller 2 and shrink, make clamping jaw 12 loosen, do not fix the reel, the roll is placed in a palletized position.
Finally, it should be noted that: although the present invention has been described in detail with reference to the foregoing embodiments, it will be apparent to those skilled in the art that modifications may be made to the embodiments described in the foregoing embodiments, or equivalents may be substituted for elements thereof. Any modification, equivalent replacement, or improvement made within the spirit and principle of the present invention should be included in the protection scope of the present invention.
Claims (6)
1. A novel ribbon palletizing robot, comprising supporting legs (1), characterized in that: the quantity of supporting leg (1) is four, two the first crossbeam of top fixedly connected with (3) of supporting leg (1), two in addition another first crossbeam of top fixedly connected with (3) of supporting leg (1), two the top of first crossbeam (3) all is provided with first drive arrangement (5), two the same second crossbeam of top fixedly connected with (14) of first drive arrangement (5), the top of second crossbeam (14) is provided with second drive arrangement (15), the side fixedly connected with electric putter (10) of second drive arrangement (15), the bottom of electric putter (10) is provided with backup pad (11), the equal swing joint in bottom both ends of backup pad (11) has clamping jaw (12), the side of supporting leg (1) is provided with controller (2).
2. A novel belt palletizer robot as claimed in claim 1, characterized in that: first drive arrangement (5) include first fixed plate (6), the side swing joint of first fixed plate (6) has first bearing wheel (9), first bearing wheel (9) overlap joint is at the top of first crossbeam (3), the side of first crossbeam (3) is provided with first rack (4), the side of first fixed plate (6) is provided with first motor (7), the output shaft surface of first motor (7) is provided with first gear (8), first gear (8) and first rack (4) intermeshing, two the bottom both ends fixed connection of first fixed plate (6) top and second crossbeam (14) of first drive arrangement (5).
3. A novel belt palletizer robot as claimed in claim 1, characterized in that: the second driving device (15) comprises a second fixing plate (16), a second bearing wheel (17) is movably connected to the side face of the second fixing plate (16), the second bearing wheel (17) is overlapped with the top of a second cross beam (14), a second motor (18) is arranged on the side face of the second fixing plate (16), a second gear (20) is arranged on the surface of an output shaft of the second motor (18), a second rack (19) is arranged on the side face of the second cross beam (14), the second gear (20) is meshed with the second rack (19), and electric push rods (10) are fixedly connected to the two sides of the second fixing plate (16).
4. A novel belt palletizer robot as claimed in claim 1, characterized in that: the controller (2) is electrically connected with the first motor (7), the second motor (18) and the electric push rod (10) through leads respectively.
5. A novel belt palletizer robot as claimed in claim 1, characterized in that: and limiting blocks are arranged at two ends of the top of the first cross beam (3) and two ends of the top of the second cross beam (14).
6. A novel belt palletizer robot as claimed in claim 1, characterized in that: two the opposite face swing joint of clamping jaw (12) has an electronic hydraulic push rod (13), electronic hydraulic push rod (13) pass through wire electric connection with controller (2).
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202021252748.8U CN212527764U (en) | 2020-07-01 | 2020-07-01 | Novel ribbon stacking robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202021252748.8U CN212527764U (en) | 2020-07-01 | 2020-07-01 | Novel ribbon stacking robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN212527764U true CN212527764U (en) | 2021-02-12 |
Family
ID=74521978
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202021252748.8U Expired - Fee Related CN212527764U (en) | 2020-07-01 | 2020-07-01 | Novel ribbon stacking robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN212527764U (en) |
-
2020
- 2020-07-01 CN CN202021252748.8U patent/CN212527764U/en not_active Expired - Fee Related
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102642078B (en) | Welding set and welding equipment for battery pole piece electrode | |
| CN114919796A (en) | Automatic stacker crane of lead-acid storage battery production assembly line | |
| CN211618226U (en) | Automatic steel pipe packing machine | |
| CN207309265U (en) | The apparatus for welding and positioning of battery pack single side stitch welding machine | |
| CN217198913U (en) | Sandwich composite strip-shaped wallboard packaging table | |
| CN203699298U (en) | Tray reshaping mechanism for tray separating machine | |
| CN211766481U (en) | Positioning device for packaging machine | |
| CN218560412U (en) | Multifunctional stacking robot composite gripper | |
| CN209740226U (en) | A hanging basket formula unloads brick packing system for environmental protection brick production | |
| CN107758365A (en) | A kind of feed manufacturing machine stacking machine | |
| CN112499275A (en) | Quick pile up neatly machine of goods for commodity circulation transportation | |
| CN217675421U (en) | Printing finished product manipulator stacking device | |
| CN217023191U (en) | Flexible container winding mechanism | |
| CN112278410B (en) | Plate packaging device | |
| CN215478366U (en) | Full-automatic rectilinear hacking machine | |
| CN215437127U (en) | Full-automatic packaging machine | |
| CN209380071U (en) | A kind of new energy resource power battery mould group multidimensional welding platform | |
| CN220641701U (en) | Heavy-load stacking structure | |
| CN215557308U (en) | Symmetrical feeding device of stacker crane | |
| CN216234915U (en) | Full-automatic stacker crane with good cargo grabbing, firm and working stability | |
| CN218144194U (en) | Stacking and feeding mechanism of storage battery assembly production line | |
| CN222361183U (en) | Electric energy meter battery box packaging equipment | |
| CN216054279U (en) | Iron core conveying device of voltage transformer winding machine | |
| CN215973972U (en) | Auxiliary device for slitting material package | |
| CN218555856U (en) | Microphone wire carrying device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20210212 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |