Workpiece feeding manipulator
Technical Field
A workpiece feeding manipulator belongs to the technical field of column head processing equipment.
Background
The column head is an important accessory of the single hydraulic column, when the column head is produced, a machine tool is required to perform operations such as turning an outer circle, end face turning and drilling on the column head, in order to improve production efficiency and achieve production automation, the column head is usually produced through an automatic production line, and feeding of the column head is achieved through a manipulator. Because the column cap is gyration type work piece, realize pressing from both sides tightly through three-jaw chuck when turning excircle and terminal surface, in order to guarantee that three-jaw chuck and column cap are coaxial, need make the terminal surface laminating of an terminal surface of column cap and three-jaw chuck, but when through the manipulator material loading, be difficult to guarantee that column cap and three-jaw chuck laminate just, appear laminating not jail or the problem of column cap and chuck collision very easily, lead to work piece machining accuracy not enough, the rejection rate of product is higher, and cause the damage to the chuck very easily.
Disclosure of Invention
The to-be-solved technical problem of the utility model is: overcome prior art's not enough, provide one kind and can play the buffering effect, guarantee the work piece material loading manipulator of work piece and lathe laminating completely.
The utility model provides a technical scheme that its technical problem adopted is: this work piece material loading manipulator, its characterized in that: the lifting device is installed on the translation device and moves horizontally along with the translation device, the workpiece clamping jaw is movably installed on the lifting device, and a buffer device is arranged between the workpiece clamping jaw and the lifting device.
Preferably, the buffer device comprises a buffer spring, one side of the lifting device is provided with a limiting part, one end of the buffer spring is supported on the lifting device, and the other end of the buffer spring pushes the workpiece clamping jaw to compress the limiting part.
Preferably, the buffering device further comprises a buffering guide rod, the buffering guide rod is arranged along the moving direction of the translation device, the buffering guide rod is installed on the lifting device, the workpiece clamping jaw is connected with the buffering guide rod in a sliding mode, and the buffering spring is sleeved outside the buffering guide rod.
Preferably, the lifting device is provided with a buffer guide rail, the buffer guide rail is arranged in parallel to the moving direction of the translation device, and the workpiece clamping jaw is slidably mounted on the buffer guide rail.
Preferably, the workpiece clamping jaw comprises a clamping plate and a clamping cylinder, the clamping plate is provided with two clamping plates which are arranged in parallel and at intervals, and the clamping cylinder is simultaneously connected with the clamping plate and pushes the clamping plate to synchronously move towards the opposite direction.
Preferably, the clamping plate is provided with clamping blocks, the middle parts of the clamping blocks are provided with arc-shaped grooves, and the grooves of the two clamping blocks surround a circular clamping part.
Preferably, the number of the lifting devices is at least two, each lifting device is connected with the translation device, and each lifting device is provided with a workpiece clamping jaw.
Preferably, the translation device comprises a translation motor and a translation frame, the translation motor is connected with the translation frame through a chain or a synchronous belt and drives the translation frame to translate, and the lifting device is installed on the translation frame and moves synchronously with the translation frame.
Preferably, the lifting device comprises a lifting cylinder, the lifting cylinder is vertically arranged on the translation device, and the workpiece clamping jaw is movably arranged on a piston rod of the lifting cylinder.
Preferably, the lifting device further comprises a vertically arranged lifting guide rail, and the workpiece clamping jaw is slidably mounted on the lifting guide rail.
Compared with the prior art, the utility model discloses the beneficial effect who has is:
1. this translation device and elevating gear of work piece material loading manipulator cooperate, drive the work piece clamping jaw and remove, thereby the automatic feeding of work piece has been realized, work piece clamping jaw and elevating gear swing joint, and be provided with buffer between work piece clamping jaw and the elevating gear, buffer can play the buffering effect when the work piece clamping jaw with the work piece centre gripping to anchor clamps on, can enough guarantee that work piece and anchor clamps laminating are reliable, guarantee that the work piece location is accurate, can avoid work piece and anchor clamps to take place the rigidity collision again, avoid causing the damage to work piece and anchor clamps.
2. Buffer spring promotes the work piece clamping jaw and compresses tightly spacing portion to can play the buffering effect when work piece and anchor clamps contact, guarantee that work piece and anchor clamps laminating are reliable, and then guarantee that the work piece location is accurate, improve the degree of accuracy of work piece processing.
3. The buffering guide rod can guide the workpiece and can also guide the buffering spring, and the force for pushing the workpiece to be clamped by the buffering spring is more stable.
4. The buffer guide rail can guide the workpiece clamping jaw, so that the workpiece clamping jaw is guaranteed to lift linearly, and workpiece feeding is guaranteed to be more accurate.
5. The clamping cylinder pushes the two clamping plates to synchronously move towards opposite directions, so that the clamping and the loosening of the workpiece are realized; the clamping block is arranged on the clamping plate, and the arc-shaped groove is formed in the middle of the clamping block, so that the workpiece can be reliably clamped when the workpiece is clamped, and clamping inaccuracy caused by looseness of the workpiece is avoided.
6. The lifting devices are at least two, and the workpiece clamping jaws correspond to the lifting devices one to one, so that a new workpiece can be placed into a fixture of the machine tool while the machined workpiece is taken down, and the workpiece clamping efficiency is high.
7. The translation motor drives the translation frame to move through a chain or a synchronous belt, so that the position of the workpiece clamping jaw is conveniently and accurately controlled, and the workpiece clamping jaw is ensured to be aligned with the clamp.
8. The lifting cylinder pushes the workpiece clamping jaw to lift, so that the workpiece clamping jaw is guaranteed to lift linearly, and the stroke of the cylinder is utilized for fixing, so that the workpiece and the clamp are accurately aligned.
9. The lifting guide rail can guide the workpiece clamping jaw, so that the workpiece clamping jaw can be ensured to be lifted linearly, and the workpiece can be ensured to be loaded accurately.
Drawings
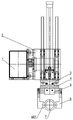
Fig. 1 is a left side sectional view of a workpiece loading robot.
Fig. 2 is a schematic front view of a workpiece loading robot.
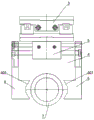
Figure 3 is a front view schematic of the workpiece jaw installation.
Figure 4 is a left side schematic view of a workpiece jaw installation.
In the figure: 1. the device comprises a cross beam 2, a translation frame 3, a lifting frame 4, an installation frame 5, a clamping cylinder 6, a clamping plate 601, a clamping part 7, a workpiece 8, a lifting guide rail 9, a lifting cylinder 10, a buffering guide rod 11, a buffering spring 12 and a connecting plate.
Detailed Description
Fig. 1 to 4 are preferred embodiments of the present invention, and the present invention will be further explained with reference to fig. 1 to 4.
The utility model provides a work piece material loading manipulator, includes translation device, elevating gear and work piece clamping jaw, and elevating gear installs on translation device to along with translation device horizontal migration, work piece clamping jaw movable mounting is provided with buffer between work piece clamping jaw and the elevating gear on elevating gear. This translation device and elevating gear of work piece material loading manipulator cooperate, drive the work piece clamping jaw and remove, thereby realized the automatic feeding of work piece 7, work piece clamping jaw and elevating gear swing joint, and be provided with buffer between work piece clamping jaw and the elevating gear, buffer can play the buffering effect when the work piece clamping jaw is with 7 centre grippings of work piece to anchor clamps, can enough guarantee that work piece 7 and anchor clamps laminating are reliable, guarantee that 7 location of work piece are accurate, can avoid work piece 7 and anchor clamps to take place the rigidity collision again, avoid causing the damage to work piece 7 and anchor clamps.
The present invention is further described with reference to specific embodiments, however, it will be understood by those skilled in the art that the detailed description given herein with respect to the drawings is for better explanation and that the present invention is necessarily to be construed as limited to those embodiments, and equivalents or common means thereof will not be described in detail but will fall within the scope of the present application.
Specifically, the method comprises the following steps: as shown in FIGS. 1-2: this work piece material loading manipulator still includes crossbeam 1, and 1 level setting of crossbeam, translation device install on crossbeam 1, and elevating gear installs on translation device, and elevating gear is provided with two at least, and in this embodiment, elevating gear is provided with two, and two elevating gear all link to each other with translation device to drive the synchronous horizontal migration of translation device. The workpiece clamping jaws are in one-to-one correspondence with the lifting devices and are movably mounted on the corresponding lifting devices, and a buffer device is arranged between each workpiece clamping jaw and the corresponding lifting device.
The translation device comprises a translation motor and a translation frame 2, a horizontal translation guide rail is installed on one side of the cross beam 1, the translation frame 2 is slidably installed on the translation guide rail, and the translation motor is installed on the cross beam 1. The translation device further comprises a chain, chain wheels are rotatably mounted at two ends of the cross beam 1, two ends of the chain are meshed with the chain wheels at corresponding ends respectively, an output shaft of a translation motor is connected with any one chain wheel and drives the same to rotate, one side of the translation frame 2, which is connected with the chain, is synchronously moved along with the chain, and the translation motor is a servo motor, so that the translation frame 2 is accurately moved.
Elevating gear includes lift cylinder 9, lifting guide 8 and crane 3, and 8 vertical installations of lifting guide are on translation frame 2, and crane 3 slidable mounting is on lifting guide 8, and 9 vertical installations of lift cylinder are on translation frame 2, and lift cylinder 9's piston rod links to each other with crane 3 to promote its straight line and go up and down.
As shown in FIGS. 3-4: the work piece clamping jaw passes through the mounting bracket 4 to be installed on crane 3, and mounting bracket 4 and crane 3 sliding connection, and be provided with buffer between mounting bracket 4 and the crane 3.
One side of crane 3 is provided with the limiting plate, forms spacing portion, and one side that mounting bracket 4 is close to the limiting plate is provided with connecting plate 12, and the lower part of connecting plate 12 links to each other with mounting bracket 4, and upper portion passes through buffer and links to each other with mounting bracket 4.
Buffer includes buffer spring 11 and buffering guide bar 10, and the one end and the crane 3 fixed connection of buffering guide bar 10, the other end links to each other with the limiting plate. Connecting plate 12 and buffering guide bar 10 sliding connection, buffer spring 11 cover is established outside buffering guide bar 10, and buffer spring 11 sets up the one side that keeps away from the limiting plate at connecting plate 12, and buffer spring 11 is in compression state, and buffer spring 11 one end is supported on crane 3, and the other end links to each other with connecting plate 12 to promote connecting plate 12 and compress tightly the limiting plate.
The crane 3 is provided with a horizontal buffer guide rail, and the installation rack 4 is slidably mounted on the crane 3, so that the installation rack 4 is ensured to move linearly.
The work piece clamping jaw is installed on mounting bracket 4, and the work piece clamping jaw includes splint 6 and die clamping cylinder 5, and die clamping cylinder 5 installs on mounting bracket 4, and splint 6 has two that parallel and interval set up, and splint 6 slidable mounting is at the downside of mounting bracket 4, and die clamping cylinder 5 has two, and every die clamping cylinder 5's piston rod all links to each other with splint 6 to promote the translation of splint 6, make two splint 6 remove to opposite direction in step, thereby realized opening and shutting of splint 6.
The vertical setting of splint 6, the upper end of splint 6 links to each other with the piston rod of the die clamping cylinder 5 who corresponds, and the lower extreme is provided with and presss from both sides tight piece, presss from both sides tight piece setting between two splint 6, and the middle part that presss from both sides tight piece is provided with curved recess, and the axis level of recess sets up, and the recess of two tight pieces of clamp encloses into circular shape clamping part to press from both sides tight cylindric work piece 7, guarantee work piece 7 level after pressing from both sides tightly, and then realized the accurate material loading of work piece 7.
The work process of this work piece material loading manipulator is as follows: the workpiece clamping jaws on the first front side clamp the workpiece 7 to be machined, the translation device drives the two workpiece clamping jaws to move to the machine tool, then the workpiece clamping jaws on the front side clamp the workpiece 7 machined on the workpiece, and then the workpiece clamping jaws on the rear side place the workpiece 7 to be machined on the machine tool.
When the workpiece 7 is placed on a fixture of a machine tool, the buffer device can ensure that the workpiece 7 is reliably attached to the fixture of the machine tool, can ensure accurate positioning of the workpiece 7, and can avoid collision of a workpiece clamping jaw with the machine tool due to the fact that inertia cannot stop.
While the invention has been described with reference to a preferred embodiment, it will be understood by those skilled in the art that various changes in form and details may be made therein without departing from the spirit and scope of the invention. However, any simple modification, equivalent change and modification made to the above embodiments according to the technical substance of the present invention still belong to the protection scope of the technical solution of the present invention.