CN212239965U - Full-automatic assembly device of block rubber preforming - Google Patents
Full-automatic assembly device of block rubber preforming Download PDFInfo
- Publication number
- CN212239965U CN212239965U CN201922400211.5U CN201922400211U CN212239965U CN 212239965 U CN212239965 U CN 212239965U CN 201922400211 U CN201922400211 U CN 201922400211U CN 212239965 U CN212239965 U CN 212239965U
- Authority
- CN
- China
- Prior art keywords
- screw
- push rod
- driving
- rubber block
- temporary storage
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images




Landscapes
- Processing And Handling Of Plastics And Other Materials For Molding In General (AREA)
Abstract
Description
技术领域technical field
本实用新型涉及自动生产设备技术领域,尤其涉及一种胶块压片全自动组装装置。The utility model relates to the technical field of automatic production equipment, in particular to an automatic assembling device for pressing rubber blocks.
背景技术Background technique
现阶段自动化生产过程中,特别是在建筑五金配件装配过程中,一般由人工组装,再手工打上螺丝,这种组装以及打螺丝方式效率低下,而且需要大量的人力投入,不适合大批量生产。In the current automated production process, especially in the assembly process of building hardware accessories, it is generally assembled manually and then screwed by hand. This assembly and screwing method is inefficient and requires a lot of human input, which is not suitable for mass production.
发明内容SUMMARY OF THE INVENTION
本实用新型的目的在于克服现有技术的不足,提供一种结构新颖自动化程度高的块、压片与螺丝的高效全自动化装置。The purpose of the utility model is to overcome the deficiencies of the prior art, and to provide a high-efficiency full-automation device for blocks, tablets and screws with novel structure and high degree of automation.
为了实现以上目的,本实用新型所采用的技术方案是:In order to achieve the above purpose, the technical scheme adopted by the present utility model is:
一种胶块压片全自动组装装置,包括转盘、用于驱动所述转盘的转盘驱动机构,所述转盘外围设置有沿所述转盘转动方向依次排列的第一进料装置、第二进料装置、打螺丝装置以及出料装置;所述第一进料装置包括胶块振动盘、胶块推料机构、连接所述胶块振动盘与胶块推料机构的胶块进料滑道以及第一机械手;所述第二进料装置包括压片振动盘、压片推料机构、连接所述压片振动盘与压片推料机构的压片进料滑道以及第二机械手;所述打螺丝装置包括有螺丝振动盘、螺丝推料机构、连接所述螺丝振动盘以及螺丝推料机构的螺丝进料滑道、螺丝暂存座、电批、电批安装支架以及电批升降单元;其中所述的螺丝推料机构包括有螺丝侧推杆、推动所述螺丝侧推杆切换第一档位和第二档位的螺丝侧推单元、螺丝正推杆以及驱动所述螺丝正推杆的螺丝正推单元,所述螺丝侧推杆侧推杆上开有配合螺丝的螺丝暂存槽,当所述螺丝侧推杆处于第一档位时所述螺丝暂存槽与螺丝进料滑道对接,当所述螺丝侧推杆处于第二档位时所述螺丝暂存槽与螺丝正推杆对准;所述螺丝正推杆用于将螺丝从螺丝暂存槽推入所述螺丝暂存座中;所述电批与电批安装支架构成竖向滑动连接并且该电批设置于所述螺丝暂存座正上方;所述出料装置包括出料滑道以及出料机械手。A fully automatic assembling device for rubber block pressing, comprising a turntable and a turntable driving mechanism for driving the turntable, the periphery of the turntable is provided with a first feeding device and a second feeding device arranged in sequence along the rotation direction of the turntable device, screwing device and discharging device; the first feeding device includes a rubber block vibrating plate, a rubber block pushing mechanism, a rubber block feeding chute connecting the rubber block vibration plate and the rubber block pushing mechanism, and a first manipulator; the second feeding device includes a tableting vibrating plate, a tableting pushing mechanism, a tableting feeding chute connecting the tableting vibration plate and the tableting pushing mechanism, and a second manipulator; the The screwing device includes a screw vibrating plate, a screw pushing mechanism, a screw feeding chute connecting the screw vibrating plate and the screw pushing mechanism, a screw temporary storage seat, an electric batch, an electric batch mounting bracket and an electric batch lifting unit; The screw pushing mechanism includes a screw side push rod, a screw side push unit that pushes the screw side push rod to switch the first gear and the second gear, a screw positive push rod, and a screw positive push rod that drives the screw side push rod The screw positive push unit, the screw side push rod side push rod is provided with a screw temporary storage slot for the screw, when the screw side push rod is in the first gear, the screw temporary storage slot and the screw feed slide When the screw side push rod is in the second gear position, the screw temporary storage slot is aligned with the screw positive push rod; the screw positive push rod is used to push the screw from the screw temporary storage slot into the screw in the temporary storage seat; the electric batch and the electric batch installation bracket form a vertical sliding connection, and the electric batch is arranged just above the screw temporary storage seat; the discharging device includes a discharging chute and a discharging manipulator.
本实用新型的有益效果是:本实用新型的自动化装置可实现胶块、压片自动上料以及螺丝连接,提高生产效率减小人力消耗。具体地,转盘在转盘驱动机构的作用下可将物料依次输送至第一进料装置、第二进料装置、打螺丝装置以及出料装置所在的工位上。第一进料装置的胶块振动盘可将胶块自动输送至胶块推料机构中并利用胶块推料机构将胶块逐个推送至待暂存的工位上,利用第一机械手将胶块夹起并移动至转盘上。第二进料装置的压片振动盘可将压片自动输送至压片推料机构中并利用压片推料机构将压片逐个推送至待暂存的工位上,利用第二机械手将压片夹起并移动至转盘上。打螺丝装置的螺丝推料机构,可通过螺丝推料机构将螺丝推送至螺丝暂存座上,由于电批设置于螺丝暂存座正上方,在电批升降单元的驱动下电批下降并将螺丝插入压片与胶块所在的螺纹孔上,并通过电批将螺丝拧紧实现压片与胶块之间螺丝连接。出料装置的出料机械手可将转盘上已完成装配的工件夹起并移动至除料滑到上利用出料滑道将工件排出。The beneficial effects of the utility model are as follows: the automatic device of the utility model can realize the automatic feeding and screw connection of the glue block and the pressing sheet, so as to improve the production efficiency and reduce the labor consumption. Specifically, under the action of the turntable drive mechanism, the turntable can sequentially transport the materials to the stations where the first feeding device, the second feeding device, the screwing device and the discharging device are located. The rubber block vibrating plate of the first feeding device can automatically transport the rubber blocks to the rubber block pushing mechanism, and use the rubber block pushing mechanism to push the rubber blocks one by one to the station to be temporarily stored. The block is picked up and moved to the turntable. The tablet vibrating plate of the second feeding device can automatically transport the tablet to the tablet pushing mechanism, and use the tablet pushing mechanism to push the tablet one by one to the station to be temporarily stored, and use the second manipulator to push the tablet. The film is picked up and moved to the turntable. The screw pushing mechanism of the screw-driving device can push the screws to the screw temporary storage seat through the screw pushing mechanism. Since the electric batch is set right above the screw temporary storage seat, the electric batch is lowered and moved by the driving of the electric batch lifting unit. The screw is inserted into the threaded hole where the pressing piece and the rubber block are located, and the screw is tightened by an electric batch to realize the screw connection between the pressing piece and the rubber block. The discharge manipulator of the discharge device can clamp the assembled workpiece on the turntable and move it to the top to remove the material and use the discharge slideway to discharge the workpiece.
进一步,所述的第一机械手、第二机械手以及出料机械手均包括有机械手支架、固定安装在所述机械手支架上的水平滑轨、滑动连接于所述水平滑轨上的水平滑座、驱动所述水平滑座滑动的机械手平移气缸、固定安装于所述水平滑座上的升降滑轨、滑动连接于所述升降滑轨上的夹紧单元、驱动所述夹紧单元升降的机械手升降气缸。Further, the first manipulator, the second manipulator and the discharging manipulator all include a manipulator bracket, a horizontal slide rail fixedly installed on the manipulator bracket, a horizontal slide seat slidably connected to the horizontal slide rail, and a drive. The manipulator translation cylinder for sliding the horizontal sliding seat, the lifting slide rail fixedly installed on the horizontal sliding seat, the clamping unit slidably connected to the lifting sliding rail, and the manipulator lifting cylinder for driving the lifting and lowering of the clamping unit .
本实用新型采用上述结构后,机械手平移气缸可带动水平滑座平移进而带动夹紧单元平移,而机械手升降气缸则可带动夹紧单元升降,通过以上方式调节加进单元在水平方向以及竖向的位置,使其动作灵活从而将物料移动使对应的位置上。After the utility model adopts the above structure, the manipulator translation cylinder can drive the horizontal sliding seat to translate and then drive the clamping unit to translate, and the manipulator lifting cylinder can drive the clamping unit to rise and fall. position, so that its action is flexible so that the material can be moved to the corresponding position.
进一步,所述的夹紧单元包括一对夹具以及带动所述夹具开合的气动手指。Further, the clamping unit includes a pair of clamps and a pneumatic finger that drives the clamps to open and close.
进一步,所述的胶块推料机构包括胶块推杆、驱动所述胶块推杆切换第一档位和第二档位的胶块推杆驱动单元;所述的胶块推杆预留有配合胶块的胶块暂存槽,当所述胶块推杆处于第一档位时所述胶块暂存槽与胶块进料滑道对接,当所述胶块推杆处于第二档位时,所述胶块暂存槽与胶块进料滑道相错。由于胶块进料滑道末端的胶块只能通过胶块推杆上的胶块暂存槽带出,因此利用胶块推杆在第一档位和第二档位之间切换可将胶块从胶块进料滑道逐个推出,以便于第一机械手取料。Further, the plastic block pushing mechanism includes a plastic block push rod, a plastic block push rod driving unit that drives the plastic block push rod to switch the first gear and the second gear; the plastic block push rod is reserved for There is a glue block temporary storage slot for the glue block. When the glue block push rod is in the first gear, the glue block temporary storage groove is connected with the glue block feeding chute. When the glue block push rod is in the second position In the gear position, the glue block temporary storage groove and the glue block feeding chute are staggered. Since the glue block at the end of the glue block feeding chute can only be taken out through the glue block temporary storage slot on the glue block push rod, the glue block push rod can be used to switch between the first gear and the second gear The blocks are pushed out one by one from the block feeding chute, so that the first manipulator can take the material.
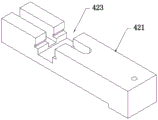
进一步,所述的压片推料机构包括胶块推杆、驱动所述压片推杆切换第一档位和第二档位的压片推杆驱动单元;所述的压片推杆预留有配合压片的压片暂存槽,当所述压片推杆处于第一档位时所述压片暂存槽与压片进料滑道对接,当所述压片推杆处于第二档位时,所述压片暂存槽与压片进料滑道相错。由于胶块压片进料滑道末端的压片只能通过压片推杆上的压片暂存槽带出,因此利用压片推杆在第一档位和第二档位之间切换可将压片从压片进料滑道逐个推出,以便于第二机械手取料。Further, the tableting pusher mechanism includes a rubber block pusher, a tableting pusher driving unit that drives the tableting pusher to switch between the first gear and the second gear; the tableting pusher is reserved for There is a temporary storage slot for tablet pressing. When the pressing push rod is in the first gear, the temporary storage slot is connected to the tablet feeding chute. When the tablet pressing rod is in the second position When in the gear position, the tablet pressing temporary storage groove and the tablet pressing feeding chute are staggered. Since the tablet at the end of the feeding chute can only be taken out through the temporary storage slot on the tablet push rod, the use of the tablet push rod to switch between the first gear and the second gear can Push the tablets out from the tablet feeding chute one by one, so that the second manipulator can take the material.
进一步,所述的转盘驱动机构包括驱动电机、减速箱、主动链轮、从动链轮以及传动链条,所述主动链轮与驱动电机同轴连接,所述从动链轮与减速箱输入轴同轴连接,所述传动链条传动连接主动链轮与从动链轮,所述减速箱的输出轴与转盘同轴连接。驱动电机通过主动链轮、从动链轮以及传动链条的传动作用将其动力传递至减速箱中,通过减速箱的扭矩放大作用将驱动转盘转动。Further, the turntable drive mechanism includes a drive motor, a reduction box, a driving sprocket, a driven sprocket and a transmission chain, the driving sprocket is coaxially connected to the driving motor, and the driven sprocket is connected to the input shaft of the reduction box. Coaxial connection, the drive chain drives and connects the driving sprocket and the driven sprocket, and the output shaft of the reduction box is coaxially connected to the turntable. The drive motor transmits its power to the reduction box through the driving action of the driving sprocket, the driven sprocket and the transmission chain, and drives the turntable to rotate through the torque amplifying action of the reduction box.
附图说明Description of drawings
图1为本实用新型的立体结构示意图。FIG. 1 is a schematic diagram of the three-dimensional structure of the present invention.
图2为本实用新型的俯视图。Figure 2 is a top view of the utility model.
图3为本实用新型的侧视图。Figure 3 is a side view of the utility model.
图4为本实用新型的第一进料装置的立体结构示意图。4 is a schematic three-dimensional structure diagram of the first feeding device of the present invention.
图5为本实用新型的胶块推杆的立体结构示意图。FIG. 5 is a schematic three-dimensional structure diagram of the rubber block push rod of the present invention.
图6为本实用新型的第二进料装置的立体结构示意图。6 is a schematic three-dimensional structure diagram of the second feeding device of the present invention.
图7为本实用新型的压片推杆的立体结构示意图。FIG. 7 is a schematic three-dimensional structure diagram of the tableting push rod of the present invention.
图8为本实用新型的打螺丝装置的立体结构示意图。FIG. 8 is a schematic three-dimensional structure diagram of the screw driving device of the present invention.
图9为本实用新型的螺丝推料机构的立体结构示意图。FIG. 9 is a schematic three-dimensional structure diagram of the screw pushing mechanism of the present invention.
图10为本实用新型的螺丝侧推杆的立体结构示意图。10 is a schematic three-dimensional structure diagram of the screw side push rod of the present invention.
图11为本实用新型的出料装置的立体结构示意图。FIG. 11 is a schematic three-dimensional structure diagram of the discharging device of the present invention.
其中,1-转盘,21-驱动电机,22-减速箱,23-主动链轮,24-从动链轮, 3-第一进料装置,31-胶块振动盘,32-胶块推料机构,321-胶块推杆,322-胶块推杆驱动单元,323-胶块暂存槽,33-胶块进料滑道,4-第二进料装置,41-压片振动盘,42-压片推料机构,421-压片推杆,422-压片推杆驱动单元,423-压片暂存槽,43-压片进料滑道,5-打螺丝装置,51-螺丝振动盘,52-螺丝推料机构,521-螺丝侧推杆,5211-螺丝暂存槽,522-螺丝侧推单元,523-螺丝正推杆,524-螺丝正推单元,53-螺丝进料滑道,54-螺丝暂存座,55-电批,56-电批安装支架,57-电批升降单元,61-出料滑道,7a-第一机械手,7b-第二机械手,7c-出料机械手,71-机械手支架,72-水平滑轨,73-水平滑座,74-机械手平移气缸,75-升降滑轨,76-夹紧单元,77-机械手升降气缸。Among them, 1- turntable, 21- drive motor, 22- reduction box, 23- driving sprocket, 24- driven sprocket, 3- first feeding device, 31- plastic block vibration plate, 32- plastic block pusher Mechanism, 321- glue block push rod, 322- glue block push rod drive unit, 323- glue block temporary storage tank, 33- glue block feeding chute, 4- second feeding device, 41- tablet vibrating plate, 42- tablet pushing mechanism, 421- tablet pushing rod, 422- tablet pushing rod drive unit, 423- tablet temporary storage slot, 43- tablet feeding chute, 5- screw device, 51- screw Vibrating plate, 52-screw pusher mechanism, 521-screw side pusher, 5211-screw temporary storage slot, 522-screw side pusher unit, 523-screw forward pusher, 524-screw forward pusher unit, 53-screw feeding Slideway, 54-screw temporary storage seat, 55-electric batch, 56-electric batch mounting bracket, 57-electric batch lifting unit, 61-discharge chute, 7a-first manipulator, 7b-second manipulator, 7c- Discharging manipulator, 71-manipulator bracket, 72-horizontal slide rail, 73-horizontal slide seat, 74-manipulator translation cylinder, 75-lifting slide rail, 76-clamping unit, 77-manipulator lifting cylinder.
具体实施方式Detailed ways
现结合附图和具体实施例对本实用新型所要求保护的技术方案作进一步详细说明。The technical solutions claimed by the present utility model will now be described in further detail with reference to the accompanying drawings and specific embodiments.
参见图1至图11所示,本实施例中的一种胶块压片全自动组装装置,包括转盘1、用于驱动所述转盘1的转盘驱动机构,所述转盘1外围设置有沿所述转盘1转动方向依次排列的第一进料装置3、第二进料装置4、打螺丝装置5以及出料装置。Referring to FIG. 1 to FIG. 11 , a fully automatic assembling device for rubber block pressing in this embodiment includes a
在本实施例中,所述的转盘驱动机构包括驱动电机21、减速箱22、主动链轮23、从动链轮24以及传动链条,所述主动链轮23与驱动电机21同轴连接,所述从动链轮24与减速箱22输入轴同轴连接,所述传动链条传动连接主动链轮23与从动链轮24,所述减速箱22的输出轴与转盘1同轴连接。驱动电机21通过主动链轮23、从动链轮24以及传动链条的传动作用将其动力传递至减速箱22中,通过减速箱22的扭矩放大作用将驱动转盘1转动。转盘1在转盘驱动机构的作用下可将物料依次输送至第一进料装置3、第二进料装置4、打螺丝装置5以及出料装置所在的工位上。In this embodiment, the turntable drive mechanism includes a drive motor 21, a
所述第一进料装置3包括胶块振动盘31、胶块推料机构32、连接所述胶块振动盘31与胶块推料机构32的胶块进料滑道33以及第一机械手7a。在本实施例中,所述的胶块推料机构32包括胶块推杆321、驱动所述胶块推杆321切换第一档位和第二档位的胶块推杆驱动单元322,其中胶块推杆驱动单元322为气缸;所述的胶块推杆321预留有配合胶块的胶块暂存槽323,当所述胶块推杆321处于第一档位时所述胶块暂存槽323与胶块进料滑道33对接,当所述胶块推杆321处于第二档位时,所述胶块暂存槽323与胶块进料滑道33相错。第一机械手7a包括有机械手支架71、固定安装在所述机械手支架71上的水平滑轨72、滑动连接于所述水平滑轨72上的水平滑座73、驱动所述水平滑座73滑动的机械手平移气缸74、固定安装于所述水平滑座73上的升降滑轨75、滑动连接于所述升降滑轨75上的夹紧单元76、驱动所述夹紧单元76升降的机械手升降气缸77。The
所述第二进料装置4包括压片振动盘41、压片推料机构42、连接所述压片振动盘41与压片推料机构42的压片进料滑道43以及第二机械手7b。在本实施例中,压片推料机构42包括压片推杆421、驱动所述压片推杆421切换第一档位和第二档位的压片推杆驱动单元422,其中压片推杆驱动单元422为气缸;所述的压片推杆421预留有配合压片的压片暂存槽423,当所述压片推杆421处于第一档位时所述压片暂存槽423与压片进料滑道43对接,当所述压片推杆421处于第二档位时,所述压片暂存槽423与压片进料滑道43相错。第二机械手7b包括有机械手支架71、固定安装在所述机械手支架71上的水平滑轨72、滑动连接于所述水平滑轨72上的水平滑座73、驱动所述水平滑座73滑动的机械手平移气缸74、固定安装于所述水平滑座73上的升降滑轨75、滑动连接于所述升降滑轨75上的夹紧单元76、驱动所述夹紧单元76升降的机械手升降气缸77。The
所述打螺丝装置5包括有螺丝振动盘51、螺丝推料机构52、连接所述螺丝振动盘51以及螺丝推料机构52的螺丝进料滑道53、螺丝暂存座54、电批55、电批安装支架56以及电批升降单元57。其中所述的螺丝推料机构52包括有螺丝侧推杆521、推动所述螺丝侧推杆521切换第一档位和第二档位的螺丝侧推单元522、螺丝正推杆523以及驱动所述螺丝正推杆523的螺丝正推单元524,所述螺丝侧推杆521侧推杆上开有配合螺丝的螺丝暂存槽5211,当所述螺丝侧推杆521处于第一档位时所述螺丝暂存槽5211与螺丝进料滑道53对接,当所述螺丝侧推杆521处于第二档位时所述螺丝暂存槽5211与螺丝正推杆523对准;所述螺丝正推杆523用于将螺丝从螺丝暂存槽5211推入所述螺丝暂存座54中;所述电批55与电批安装支架56构成竖向滑动连接并且该电批55设置于所述螺丝暂存座54正上方。在本实施例中螺丝侧推单元522、螺丝正推单元524以及电批升降单元57均未气缸。The screwing
所述出料装置包括出料滑道61以及出料机械手7c。出料机械手7c包括有机械手支架71、固定安装在所述机械手支架71上的水平滑轨72、滑动连接于所述水平滑轨72上的水平滑座73、驱动所述水平滑座73滑动的机械手平移气缸74、固定安装于所述水平滑座73上的升降滑轨75、滑动连接于所述升降滑轨75上的夹紧单元76、驱动所述夹紧单元76升降的机械手升降气缸77。The discharging device includes a discharging
本实施例的工作过程如下:The working process of this embodiment is as follows:
S1. 第一进料装置3的胶块振动盘31可将胶块自动输送至胶块推料机构32中并利用胶块推料机构32将胶块逐个推送至待暂存的工位上,利用第一机械手7a将胶块夹起并移动至转盘1上。具体地,胶块进料滑道33末端的胶块通过胶块推杆321上的胶块暂存槽323带出,胶块推杆321在第一档位和第二档位之间切换可将胶块从胶块进料滑道33逐个推出,当胶块推杆321切换至第二档位后,第一机械手7a取料将胶块暂存槽323中的胶块夹起并移动至转盘1上。S1. The glue
S2.第二进料装置4的压片振动盘41可将压片自动输送至压片推料机构42中并利用压片推料机构42将压片逐个推送至待暂存的工位上,利用第二机械手7b将压片夹起并移动至转盘1上。具体地,压片进料滑道43末端的压片通过压片推杆421上的压片暂存槽423带出,压片推杆421在第一档位和第二档位之间切换可将压片从压片进料滑道43逐个推出,当压片推杆421切换至第二档位后,第一机械手7a取料将压片暂存槽423中的压片夹起并移动至转盘1上。S2. The
S3. 打螺丝装置5的螺丝推料机构52,可通过螺丝推料机构52将螺丝推送至螺丝暂存座54上,具体地螺丝侧推杆521的螺丝暂存槽5211可将螺丝进料滑道53的螺丝逐个推出,当螺丝侧推杆521切换至第二档位后螺丝暂存槽5211与螺丝正推杆523对准,此时通过螺丝正推杆523将螺丝推入螺丝暂存座54中,从而将螺丝逐个移动至入螺丝暂存座54内。由于电批55设置于螺丝暂存座54正上方,在电批升降单元57的驱动下电批55下降并将螺丝插入压片与胶块所在的螺纹孔上,并通过电批55将螺丝拧紧实现压片与胶块之间螺丝连接。S3. The
S4.出料装置的出料机械手7c可将转盘1上已完成装配的工件夹起并移动至除料滑到上利用出料滑道61将工件排出。S4. The discharging
以上所述之实施例仅为本实用新型的较佳实施例,并非对本实用新型做任何形式上的限制。任何熟悉本领域的技术人员,在不脱离本实用新型技术方案范围情况下,都可利用上述揭示的技术内容对本实用新型技术方案作出更多可能的变动和润饰,或修改为等同变化的等效实施例。故凡未脱离本实用新型技术方案的内容,依据本实用新型之思路所作的等同等效变化,均应涵盖于本实用新型的保护范围内。The above-mentioned embodiments are only preferred embodiments of the present invention, and do not limit the present invention in any form. Any person skilled in the art, without departing from the scope of the technical solution of the present invention, can use the technical content disclosed above to make more possible changes and modifications to the technical solution of the present invention, or modify it into an equivalent of an equivalent change. Example. Therefore, all equivalent and equivalent changes made according to the ideas of the present utility model without departing from the content of the technical solution of the present utility model shall be covered within the protection scope of the present utility model.
Claims (6)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201922400211.5U CN212239965U (en) | 2019-12-27 | 2019-12-27 | Full-automatic assembly device of block rubber preforming |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201922400211.5U CN212239965U (en) | 2019-12-27 | 2019-12-27 | Full-automatic assembly device of block rubber preforming |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN212239965U true CN212239965U (en) | 2020-12-29 |
Family
ID=73972811
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201922400211.5U Expired - Fee Related CN212239965U (en) | 2019-12-27 | 2019-12-27 | Full-automatic assembly device of block rubber preforming |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN212239965U (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110977463A (en) * | 2019-12-27 | 2020-04-10 | 广东合和建筑五金制品有限公司 | Full-automatic assembly device of block rubber preforming |
| CN113953816A (en) * | 2021-07-28 | 2022-01-21 | 深圳市新创佳光电科技有限公司 | Novel automatic assembling equipment for cover plate machining |
-
2019
- 2019-12-27 CN CN201922400211.5U patent/CN212239965U/en not_active Expired - Fee Related
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110977463A (en) * | 2019-12-27 | 2020-04-10 | 广东合和建筑五金制品有限公司 | Full-automatic assembly device of block rubber preforming |
| CN110977463B (en) * | 2019-12-27 | 2024-06-18 | 广东合和建筑五金制品有限公司 | A fully automatic assembly device for rubber block pressing |
| CN113953816A (en) * | 2021-07-28 | 2022-01-21 | 深圳市新创佳光电科技有限公司 | Novel automatic assembling equipment for cover plate machining |
| CN113953816B (en) * | 2021-07-28 | 2022-09-13 | 深圳市新创佳光电科技有限公司 | Automatic assembling equipment for cover plate machining |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN201105371Y (en) | Semi-automatic clamping machine | |
| CN208020782U (en) | Box body and cover assembly press shaft device | |
| CN107482244A (en) | Battery automatic shelling machine | |
| CN108321659A (en) | Full-automatic assembly production line for switch sockets | |
| CN207873614U (en) | A kind of electrical appliance kit apparatus automatization assembling | |
| CN209223571U (en) | A kind of Crankshaft Machining production line | |
| CN207611957U (en) | A fully automatic assembly machine for blood glucose meter connectors | |
| CN110480328B (en) | Automatic spring sheet mounting machine for automobile ventilation panel | |
| CN221796174U (en) | Automatic cup feeding device | |
| CN212043463U (en) | Automatic assembling equipment for down lamp | |
| CN116038336A (en) | Automatic punching double-sided chamfering machine for screw pin holes and use method thereof | |
| CN119456841A (en) | Automatic feeding device for metal sheet stamping | |
| CN221834355U (en) | Servo horizontal-walking type feeding and discharging manipulator | |
| CN110977463B (en) | A fully automatic assembly device for rubber block pressing | |
| CN217747848U (en) | Full-automatic magnetic core coil point gum machine | |
| CN212239966U (en) | Automatic assembly device of spring steel ball | |
| CN213289352U (en) | Toy screw installation device | |
| CN210590643U (en) | Plastic parts automatic assembly equipment | |
| CN116873562A (en) | Transfer equipment, control method thereof and sheet processing method | |
| CN212169572U (en) | A photovoltaic junction box assembly device | |
| CN204915058U (en) | Marking machine pay -off unloader | |
| CN210914229U (en) | Loading and unloading device | |
| CN207696324U (en) | New mechanical arm | |
| CN210451882U (en) | Clamping equipment for milling groove machining of mining machinery | |
| CN216862880U (en) | Multi-station intelligent spiral transmission device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20201229 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |