CN211895068U - An automatic feeding mechanism for loading circuit boards and embryos in stacked trays - Google Patents
An automatic feeding mechanism for loading circuit boards and embryos in stacked trays Download PDFInfo
- Publication number
- CN211895068U CN211895068U CN202020373180.9U CN202020373180U CN211895068U CN 211895068 U CN211895068 U CN 211895068U CN 202020373180 U CN202020373180 U CN 202020373180U CN 211895068 U CN211895068 U CN 211895068U
- Authority
- CN
- China
- Prior art keywords
- tray
- carrier
- feeding mechanism
- unit
- automatic feeding
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
- 230000007246 mechanism Effects 0.000 title claims abstract description 33
- 210000002257 embryonic structure Anatomy 0.000 title claims abstract description 17
- 238000011084 recovery Methods 0.000 claims abstract description 23
- 239000000969 carrier Substances 0.000 claims abstract description 9
- 238000012546 transfer Methods 0.000 claims abstract description 8
- 239000000463 material Substances 0.000 claims description 31
- 230000005540 biological transmission Effects 0.000 claims description 7
- 230000000903 blocking effect Effects 0.000 claims description 7
- 230000001360 synchronised effect Effects 0.000 claims description 7
- 239000013307 optical fiber Substances 0.000 claims description 4
- 238000009826 distribution Methods 0.000 claims description 2
- 238000001514 detection method Methods 0.000 abstract description 6
- 238000000034 method Methods 0.000 description 7
- 238000010586 diagram Methods 0.000 description 6
- 230000008569 process Effects 0.000 description 6
- 239000000919 ceramic Substances 0.000 description 5
- 210000001161 mammalian embryo Anatomy 0.000 description 4
- 238000004519 manufacturing process Methods 0.000 description 4
- 230000009471 action Effects 0.000 description 3
- 230000033001 locomotion Effects 0.000 description 3
- 238000012545 processing Methods 0.000 description 3
- 230000000007 visual effect Effects 0.000 description 3
- 229910010293 ceramic material Inorganic materials 0.000 description 2
- 239000000835 fiber Substances 0.000 description 2
- 240000004282 Grewia occidentalis Species 0.000 description 1
- 230000009286 beneficial effect Effects 0.000 description 1
- 125000004122 cyclic group Chemical group 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 238000001914 filtration Methods 0.000 description 1
- 229910052451 lead zirconate titanate Inorganic materials 0.000 description 1
- HFGPZNIAWCZYJU-UHFFFAOYSA-N lead zirconate titanate Chemical compound [O-2].[O-2].[O-2].[O-2].[O-2].[Ti+4].[Zr+4].[Pb+2] HFGPZNIAWCZYJU-UHFFFAOYSA-N 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 238000002360 preparation method Methods 0.000 description 1
- 238000004064 recycling Methods 0.000 description 1
- 229910052709 silver Inorganic materials 0.000 description 1
- 239000004332 silver Substances 0.000 description 1
- 238000003860 storage Methods 0.000 description 1
- 238000012360 testing method Methods 0.000 description 1
Images


Landscapes
- De-Stacking Of Articles (AREA)
- Specific Conveyance Elements (AREA)
- Sheets, Magazines, And Separation Thereof (AREA)
Abstract
本实用新型揭示了一种堆叠式料盘装载电路板与胚体的自动上料机构,其包括平行设置的料盘输送线、NG输送线与载具输送线、分别设置在所述料盘输送线前后端的料盘供应单元与空料盘回收单元、设置于所述料盘供应单元与所述空料盘回收单元之间的料盘定位单元、沿所述载具输送线设置的载具供应单元与载具定位单元、将多个产品从所述料盘输送线上的料盘中逐个抓取放置到所述载具输送线上的载具中的产品移载装置。本实用新型能够实现装载胚体的堆叠式料盘的逐个输出与空料盘的自动回收、以及载具的自动供应上料,并将胚体逐个快速的放置在载具中实现自动检测,最后自动输出装满合格胚体产品的载具。
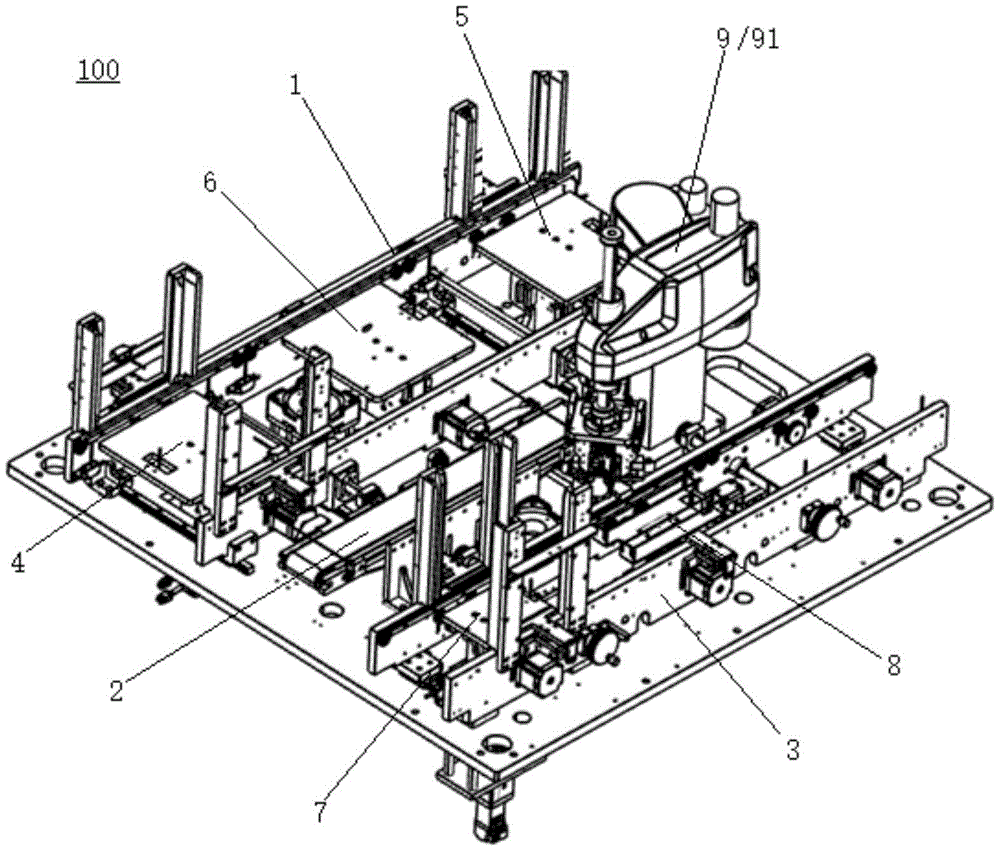
The utility model discloses an automatic feeding mechanism for loading circuit boards and embryos in a stacking tray, which comprises a tray conveying line, an NG conveying line and a carrier conveying line arranged in parallel, which are respectively arranged on the tray for conveying A tray supply unit and an empty tray recovery unit at the front and rear ends of the line, a tray positioning unit arranged between the tray supply unit and the empty tray recovery unit, and a carrier supply set along the carrier conveying line A unit and a carrier positioning unit, a product transfer device that picks up a plurality of products one by one from the trays on the tray conveyor line and places them into the carriers on the carrier conveyor line. The utility model can realize the one-by-one output of the stacking trays loaded with the embryos, the automatic recovery of the empty trays, and the automatic supply and feeding of the carrier, and the embryos can be quickly placed in the carrier one by one to realize automatic detection. Automatically output a carrier full of qualified embryonic body products.
Description
技术领域technical field
本实用新型属于陶瓷滤波器制备设备技术领域,特别是涉及一种堆叠式料盘装载电路板与胚体的自动上料机构。The utility model belongs to the technical field of ceramic filter preparation equipment, in particular to an automatic feeding mechanism for loading circuit boards and embryos in a stacking tray.
背景技术Background technique
陶瓷滤波器是由锆钛酸铅陶瓷材料制成的,把这种陶瓷材料制成片状,两面涂银作为电极,经过直流高压极化后就具有压电效应。起滤波的作用,具有稳定,抗干扰性能良好的特点,广泛应用于电视机、录像机、收音机等各种电子产品中作选频元件。它具有性能稳定、无需调整、价格低等优点,取代了传统的LC滤波网络。陶瓷滤波器包括胚体、贴合在胚体上的PCB板,在制作过程中,需要将滤波器胚体与PCB板进行贴合,这一过程称为贴片。本公司研发了一条陶瓷滤波器全自动生产流水线。其中滤波器胚体制作完成后是放置在料盘中的,一个料盘中放置有多个胚体,在胚体进入下一道印刷工序前,对胚体的高度公差要求非常严格,因此,胚体在进入流水线之前一定要严格控制其高度尺寸,胚体在进行后续的工艺时,也需要装载在一个工装载具中,以便后续加工。目前还没有一种自动供料上料机构来满足陶瓷电路板生产流水线的自动供料。The ceramic filter is made of lead zirconate titanate ceramic material. This ceramic material is made into a sheet and coated with silver on both sides as electrodes. After being polarized by DC high voltage, it has a piezoelectric effect. It plays the role of filtering, has the characteristics of stability and good anti-interference performance, and is widely used as a frequency selection component in various electronic products such as TV sets, video recorders, and radios. It has the advantages of stable performance, no adjustment, and low price, replacing the traditional LC filter network. The ceramic filter includes an embryo body and a PCB board attached to the embryo body. During the production process, the filter embryo body needs to be attached to the PCB board, which is called patching. The company has developed a fully automatic production line for ceramic filters. Among them, the filter embryos are placed in the tray after the production is completed. There are multiple embryos placed in one tray. Before the embryos enter the next printing process, the height tolerance of the embryos is very strict. The height and size of the body must be strictly controlled before entering the assembly line, and the embryo body also needs to be loaded in a tool carrier for subsequent processing during the subsequent process. At present, there is no automatic feeding and feeding mechanism to meet the automatic feeding of ceramic circuit board production lines.
因此,有必要提供一种新的堆叠式料盘装载电路板与胚体的自动上料机构来解决上述问题。Therefore, it is necessary to provide a new automatic feeding mechanism for loading circuit boards and blanks on stacked trays to solve the above problems.
发明内容SUMMARY OF THE INVENTION
本实用新型的主要目的在于提供一种堆叠式料盘装载电路板与胚体的自动上料机构,能够实现装载胚体的堆叠式料盘的逐个输出与空料盘的自动回收、以及载具的自动供应上料,并将胚体逐个快速的放置在载具中实现自动检测,最后自动输出装满合格胚体产品的载具。The main purpose of the present utility model is to provide an automatic feeding mechanism for loading circuit boards and blanks on stacked trays, which can realize the one-by-one output of the stacked trays loaded with blanks and the automatic recovery of empty trays, as well as the carrier Automatic feeding and feeding, and quickly place the embryos one by one in the carrier to realize automatic detection, and finally automatically output the carrier filled with qualified embryonic products.
本实用新型通过如下技术方案实现上述目的:一种堆叠式料盘装载电路板与胚体的自动上料机构,其包括平行设置的料盘输送线、NG输送线与载具输送线、分别设置在所述料盘输送线前后端的料盘供应单元与空料盘回收单元、设置于所述料盘供应单元与所述空料盘回收单元之间的料盘定位单元、沿所述载具输送线设置的载具供应单元与载具定位单元、将多个产品从所述料盘输送线上的料盘中逐个抓取放置到所述载具输送线上的载具中的产品移载装置。The utility model achieves the above purpose through the following technical solutions: an automatic feeding mechanism for loading circuit boards and embryos in a stacking tray, which includes a tray conveying line, a NG conveying line and a carrier conveying line, which are arranged in parallel. A tray supply unit and an empty tray recovery unit at the front and rear ends of the tray conveying line, a tray positioning unit disposed between the tray supply unit and the empty tray recovery unit, conveying along the carrier A carrier supply unit and a carrier positioning unit provided on the line, and a product transfer device that picks up a plurality of products from the trays on the tray conveyor line one by one and places them into the carriers on the carrier conveyor line .
进一步的,所述料盘输送线与所述载具输送线均包括第一侧输送模组、与所述第一侧输送模组平行设置且与其配合形成输送线的第二侧输送模组、调节所述第一输送模组与所述第二侧输送模组之间宽度的调节单元。Further, both the tray conveying line and the carrier conveying line include a first side conveying module, a second side conveying module arranged in parallel with the first side conveying module and cooperating with it to form a conveying line, An adjustment unit for adjusting the width between the first conveying module and the second side conveying module.
进一步的,所述第一侧输送模组与所述第二侧输送模组均包括第一支撑板,所述第一支撑板上至少设置有三段独立的输送单元;Further, both the first side conveying module and the second side conveying module include a first support plate, and at least three sections of independent conveying units are arranged on the first support plate;
在所述料盘输送线中,所述料盘供应单元、所述料盘定位单元与所述料盘回收单元三者分别对应于三段独立的输送单元分布;In the tray conveying line, the tray supply unit, the tray positioning unit and the tray recovery unit correspond to the distribution of three independent conveying units respectively;
在所述载具输送线中,三段独立的所述输送单元分别对应于所述载具供应单元、所述载具定位单元以及载具输出段。In the carrier conveying line, the three independent conveying units correspond to the carrier supply unit, the carrier positioning unit and the carrier output section respectively.
进一步的,所述调节单元包括通过同步带和同步带轮实现同步旋转的支撑螺杆、固定在所述支撑螺杆一端的旋转驱动手轮、平行设置的一对滑轨,所述第一侧输送模组固定设置,所述第二输送模组位置可调的设置在所述滑轨上并通过锁紧螺丝实现位置锁紧。Further, the adjustment unit includes a support screw that realizes synchronous rotation through a synchronous belt and a synchronous pulley, a rotary drive hand wheel fixed at one end of the support screw, and a pair of slide rails arranged in parallel. The group is fixedly arranged, and the position of the second conveying module is adjustable on the sliding rail, and the position is locked by a locking screw.
进一步的,所述料盘供应单元、所述空料盘回收单元以及所述载具供应单元均包括位于输送线上方的料仓、位于所述料仓底部的第一支撑托板、驱动所述第一支撑托板上下运动的第二驱动件、将所述料仓中倒数第二层及以上的物料托住的托料机构。Further, the tray supply unit, the empty tray recovery unit, and the carrier supply unit all include a silo above the conveying line, a first support plate at the bottom of the silo, and a drive to drive the silo. A second driving member that moves up and down the first support pallet, and a material support mechanism that supports the materials on the penultimate layer and above in the silo.
进一步的,所述托料机构设置有两个且对称设置在所述料仓的左右两侧,其包括第一气缸、受所述第一气缸驱动插入或抽出所述料仓内的托料板。Further, the material supporting mechanism is provided with two and symmetrically arranged on the left and right sides of the silo, which includes a first cylinder, a material supporting plate that is driven by the first cylinder to be inserted into or pulled out of the silo. .
进一步的,所述料盘定位单元包括第三驱动件、受所述第三驱动件驱动进行上下运动的第二支撑托板、固定在所述第二支撑托板前端的阻挡挡块。Further, the material tray positioning unit includes a third driving member, a second supporting plate driven by the third driving member to move up and down, and a blocking block fixed on the front end of the second supporting plate.
进一步的,所述产品移载装置包括SCARA机器人、设置在所述SCARA机器人活动末端的支撑架、固定在所述支撑架上的第五驱动件、受所述第五驱动件驱动进行上下运动的吸取装置、设置在所述支撑架上的视觉模组。Further, the product transfer device includes a SCARA robot, a support frame disposed at the movable end of the SCARA robot, a fifth drive member fixed on the support frame, and an up-and-down motor driven by the fifth drive member. A suction device and a vision module arranged on the support frame.
进一步的,所述支撑架上设置有受所述第五驱动件驱动进行循环移动的传动带,所述吸取装置设置有两个且分别通过连接件固定在所述传动带的两侧上;所述吸取装置包括旋转电机、受所述旋转电机驱动进行旋转的吸嘴。Further, the support frame is provided with a transmission belt that is driven by the fifth driving member to move cyclically, and the suction devices are provided with two and are respectively fixed on both sides of the transmission belt through connecting pieces; The device includes a rotary motor and a suction nozzle driven by the rotary motor to rotate.
进一步的,所述载具定位单元包括位于所述载具输送线下方的第二气缸、受所述第二气缸驱动进行上下运动的定位板、位于所述定位板前端的前端定位挡块、驱动所述前端定位挡块上下运动的第三气缸、位于所述定位板左右两侧的侧方定位推块、驱动所述侧方定位推块进行水平直线运动的第四气缸;所述定位板的前后端设置有向上翻着形成的挡片,所述挡片上设置有若干检测产品厚度的检测光纤。Further, the carrier positioning unit includes a second cylinder located below the carrier conveying line, a positioning plate driven by the second cylinder to move up and down, a front-end positioning block located at the front end of the positioning plate, a driving The third cylinder that moves the front-end positioning block up and down, the side positioning push blocks located on the left and right sides of the positioning plate, and the fourth cylinder that drives the lateral positioning push blocks to move horizontally and linearly; The front and rear ends are provided with baffles that are turned up and formed, and a plurality of detection fibers for detecting the thickness of the product are arranged on the baffles.
与现有技术相比,本实用新型一种堆叠式料盘装载电路板与胚体的自动上料机构的有益效果在于:实现了装载有产品的堆叠式料盘中产品的自动供料、堆叠式载具的逐个输出供料,并实现空料盘的堆叠式回收,再将产品逐个的放置于载具中,同时对产品进行检测,整个过程实现了全自动化操作;且配合SCARA机器人实现产品的移动,搬运效率高;且在SCARA机器人上设置有视觉模组,通过视觉模组配合提高了产品在载具中放置位置的精度,在产品抓取动作、产品放置位置、载具位置全过程进行控制,大大提高了产品的位置精度,为后续的产品高精度加工提供了前提基础;且料盘输送线与载具输送线均设置有调节机构,可适用于各种不同规格产品的自动输送。Compared with the prior art, the beneficial effect of the automatic feeding mechanism for loading circuit boards and embryos in a stacking tray of the present invention is that the automatic feeding and stacking of products in the stacking trays loaded with products is realized. One-by-one output and feeding of the type carriers, and the stacking recovery of empty trays is realized, and then the products are placed in the carriers one by one, and the products are inspected at the same time. The whole process is fully automated. The SCARA robot is equipped with a vision module, which improves the accuracy of the placement of the product in the carrier through the cooperation of the vision module. During the whole process of product grabbing, product placement, and carrier position Control, which greatly improves the positional accuracy of the product, and provides a premise for the subsequent high-precision processing of the product; and the tray conveying line and the carrier conveying line are equipped with adjustment mechanisms, which are suitable for automatic conveying of products of various specifications. .
【附图说明】【Description of drawings】
图1为本实用新型实施例的结构示意图;Fig. 1 is the structural representation of the utility model embodiment;
图2为本实用新型实施例中料盘输送线的结构示意图;Fig. 2 is the structural representation of the tray conveying line in the embodiment of the utility model;
图3为本实用新型实施例中料盘输送线的局部结构示意图;Fig. 3 is the partial structure schematic diagram of the tray conveying line in the embodiment of the present utility model;
图4为本实用新型实施例中料盘供应单元中的支撑托板的结构示意图;4 is a schematic structural diagram of a support pallet in a tray supply unit in an embodiment of the present invention;
图5为本实用新型实施例中料盘定位单元的结构示意图;5 is a schematic structural diagram of a tray positioning unit in an embodiment of the present invention;
图6为本实用新型实施例中NG输送线的结构示意图;6 is a schematic structural diagram of an NG conveying line in an embodiment of the present utility model;
图7为本实用新型实施例中支撑架上部件的结构示意图;Fig. 7 is the structural schematic diagram of the upper part of the support frame in the embodiment of the present invention;
图8为本实用新型实施例中载具定位单元的结构示意图;8 is a schematic structural diagram of a carrier positioning unit in an embodiment of the present invention;
图中数字表示:The numbers in the figure represent:
100堆叠式料盘装载电路板与胚体的自动上料机构;101产品;100 Automatic feeding mechanism for loading circuit boards and blanks on stacked trays; 101 products;
1料盘输送线,11第一侧输送模组,12第二侧输送模组,111第一支撑板,112输送单元,113第一驱动件,114第一输送带,13调节单元,131支撑螺杆,132旋转驱动手轮,133滑轨;1 Tray conveyor line, 11 First side conveyor module, 12 Second side conveyor module, 111 First support plate, 112 Conveyor unit, 113 First drive member, 114 First conveyor belt, 13 Adjustment unit, 131 Support Screw, 132 rotary drive handwheel, 133 slide rail;
2 NG输送线,21第四驱动件,22第二输送带;2 NG conveyor line, 21 fourth drive, 22 second conveyor belt;
3载具输送线;3 carrier conveyor line;
4料盘供应单元,41料仓,411竖向挡板,412传感器,42第一支撑托板,43第二驱动件,44托料机构,441第一气缸,442托料板;4. Material tray supply unit, 41. Material storage bin, 41.1 Vertical baffle plate, 412. Sensor, 42. First support plate, 43. Second drive member, 44. Material support mechanism, 441. First cylinder, 442. Material support plate;
5空料盘回收单元;5 Empty tray recovery unit;
6料盘定位单元,61第三驱动件,62第二支撑托板,63阻挡挡块;6. The tray positioning unit, 61. the third driving part, 62. the second supporting plate, 63. the blocking block;
7载具供应单元;7 vehicle supply units;
8载具定位单元,81第二气缸,82定位板,83前端定位挡块,84第三气缸,85侧方定位推块,86第四气缸,87挡片,88检测光纤;8 carrier positioning unit, 81 second cylinder, 82 positioning plate, 83 front end positioning block, 84 third cylinder, 85 side positioning push block, 86 fourth cylinder, 87 stopper, 88 detection fiber;
9产品移载装置,91SCARA机器人,92支撑架,93第五驱动件,94吸取装置,941旋转电机,942吸嘴,95视觉模组。9 product transfer device, 91 SCARA robot, 92 support frame, 93 fifth drive, 94 suction device, 941 rotary motor, 942 suction nozzle, 95 vision module.
【具体实施方式】【Detailed ways】
实施例:Example:
请参照图1-图8,本实施例一种堆叠式料盘装载电路板与胚体的自动上料机构100,其包括平行设置的料盘输送线1、NG输送线2与载具输送线3、分别设置在料盘输送线1前后端的料盘供应单元4与空料盘回收单元5、设置于料盘供应单元4与空料盘回收单元5之间的料盘定位单元6、沿载具输送线3设置的载具供应单元7与载具定位单元8、将多个产品从料盘输送线1上的料盘中逐个抓取放置到载具输送线3上的载具中的产品移载装置9。Referring to FIGS. 1-8 , in this embodiment, an
料盘输送线1与载具输送线3结构相同且均包括第一侧输送模组11、与第一侧输送模组11平行设置且与其配合形成输送线的第二侧输送模组12、调节第一输送模组11与第二侧输送模组12之间宽度的调节单元13。The
第一侧输送模组11与第二侧输送模组12结构相同且均包括第一支撑板111,第一支撑板111上至少设置有三段独立的输送单元112,所述输送单元112包括固定在第一支撑板111上的第一驱动件113、受第一驱动件113驱动进行循环输送的第一输送带114。在所述料盘输送线1中,所述料盘供应单元4、所述料盘定位单元6与所述料盘回收单元5三者分别对应于三段独立的输送单元112分布;在所述载具输送线中,三段独立的所述输送单元112分别对应于所述载具供应单元7、所述载具定位单元8以及载具输出段。首尾的输送单元112根据启停需求,分别实现料盘供应单元4中堆叠料盘的逐个输出、实现料盘回收单元5对料盘的逐个堆叠收回。The first side conveying module 11 and the second
调节单元13包括通过同步带和同步带轮实现同步旋转的支撑螺杆131、固定在支撑螺杆131一端的旋转驱动手轮132、平行设置的一对滑轨133。第一侧输送模组11固定设置,第二输送模组12位置可调的设置在滑轨133上并通过锁紧螺丝实现位置锁紧。通过旋转驱动手轮132转动支撑螺杆131旋转,利用丝杆螺母传动原理实现第二侧输送模组12的位置调节,从而调节第一侧输送模组11与第二侧输送模组12之间的距离,以适用于各种不同规格料盘或载具的输送。The adjustment unit 13 includes a
料盘供应单元4、空料盘回收单元5以及载具供应单元7结构原理相同且均包括位于输送线上方的料仓41、位于料仓41底部的第一支撑托板42、驱动第一支撑托板42上下运动的第二驱动件43、将料仓41中倒数第二层及以上的物料托住的托料机构44。料仓41包括固定在第一支撑板111上的且形成四角围挡结构的竖向挡板411。料仓41上还设置有感应料仓41内部物料高度的传感器412。托料机构44设置有两个对称设置在料仓41的左右两侧且包括第一气缸441、受第一气缸441驱动插入或抽出料仓41内的托料板442。The
料盘供应单元4与载具供应单元7在实现物料供应时,堆叠状的物料放置在第一支撑托板42上,然后通过第二驱动件43上升至设定高度,使得托料机构44中的托料板442伸出时刚好可以插入最底层物料与倒数第二层物料之间,然后托住倒数第二层物料,此时第一支撑托板42上只有一层物料,然后下降将物料落在输送带上并输出;然后第一支撑托板42上升托住剩下的物料,托料板442退出,第一支撑托板42下降一层物料高度,使得托料板442再次伸出时能够将倒数第二层物料托起,重复上述动作从而实现堆叠状物料从底部逐个输出的功能。When the
空料盘回收单元5在实现料盘回收时,空料盘从输送线上进入料仓41底部,然后第一支撑托板42托住空料盘向上,托料板442伸出,第一支撑托板42将空料盘放在托料板442上,然后第一支撑托板42下降至输送线下方,待下一个空料盘进入后再将该空料盘托起向上,当两个空料盒相叠时,托料板442退出,然后第一支撑托板42继续上升,托料板442伸出,第一支撑托板42下降,将堆叠状的空料盘放在托料板442上,重复上述动作从而完成空料盘从料仓底部实现逐步自动回收。When the empty
料盘定位单元6包括第三驱动件61、受第三驱动件61驱动进行上下运动的第二支撑托板62、固定在第二支撑托板62前端的阻挡挡块63。The
NG输送线2位于料盘输送线1与载具输送线3之间,且包括第四驱动件21、受第四驱动件21驱动进行循环输送的第二输送带22。The
产品移载装置9包括SCARA机器人91、设置在SCARA机器人91活动末端的支撑架92、固定在支撑架92上的第五驱动件93、受第五驱动件93驱动进行上下运动的吸取装置94、设置在支撑架92上的视觉模组95。本实施例中,支撑架92上设置有受第五驱动件93驱动进行循环移动的传动带(图中未标识),吸取装置94设置有两个且分别通过连接件固定在所述传动带的两侧上。吸取装置94包括旋转电机941、受旋转电机941驱动进行旋转的吸嘴942。通过视觉模组95连接上位机实现产品位置的自动识别,为SCARA机器人91驱动吸取装置94移动准确的吸取产品和放置产品提供了依据。通过第五驱动件93驱动两个吸取装置94一上一下交替进行上下运动,实现两个产品的同时搬运。The product transfer device 9 includes a SCARA robot 91, a
载具定位单元8包括位于载具输送线3下方的第二气缸81、受第二气缸81驱动进行上下运动的定位板82、位于定位板82前端的前端定位挡块83、驱动前端定位挡块83上下运动的第三气缸84、位于定位板82左右两侧的侧方定位推块85、驱动侧方定位推块85进行水平直线运动的第四气缸86。定位板82的前后端设置有向上翻着形成的挡片87,挡片87上设置有若干检测产品厚度的检测光纤88。挡片87一方面用于安装检测光纤88,另一方面用于与前端定位挡块83配合实现载具前后端位置的定位。The carrier positioning unit 8 includes a
一种堆叠式料盘装载电路板与胚体的自动上料机构100的工作原理为:装满产品的料盘呈堆叠状态放置于料盘供应单元4中的料仓41中,并通过第一支撑托板42托住,通过料盘供应单元4实现料盘的逐个输出,单个装满产品的料盘在料盘输送线1上从料盘供应单元4输出,然后经过料盘定位单元6定位顶起;同时,堆叠的若干载具放置于载具供应单元7中的料仓41中,并通过第一支撑托板42托住,通过载具供应单元7实现逐个输出,单个载具在载具输送线3上从载具供应单元7输出,然后到达载具定位单元8位置,通过载具定位单元8对载具的前后左右位置进行精准定位;SCARA机器人91驱动吸取装置94至定位好的料盘上方,通过视觉模组95获取料盘中产品的位置,然后吸取其中两个产品移动至载具定位单元8位置处的载具中,同时通过检测光纤88对产品高度进行检测,若检测不合格,吸取装置94吸取NG产品至NG输送线2上输出,吸取装置94再吸取一个产品补上,待载具中的装满全部合格的产品后再落回至载具输送线3上输出至下一工站;同时,料盘输送线1上空的料盘再通过料盘输送线1输入空料盘回收单元5中堆叠起来。The working principle of an
本实施例一种堆叠式料盘装载电路板与胚体的自动上料机构100实现了装载有产品的堆叠式料盘中产品的自动供料、堆叠式载具的逐个输出供料,并实现空料盘的堆叠式回收,再将产品逐个的放置于载具中,同时对产品进行检测,整个过程实现了全自动化操作;且配合SCARA机器人实现产品的移动,搬运效率高;且在SCARA机器人上设置有视觉模组,通过视觉模组配合提高了产品在载具中放置位置的精度,在产品抓取动作、产品放置位置、载具位置全过程进行控制,大大提高了产品的位置精度,为后续的产品高精度加工提供了前提基础;且料盘输送线与载具输送线均设置有调节机构,可适用于各种不同规格产品的自动输送。In this embodiment, an
以上所述的仅是本实用新型的一些实施方式。对于本领域的普通技术人员来说,在不脱离本实用新型创造构思的前提下,还可以做出若干变形和改进,这些都属于本实用新型的保护范围。The above are only some embodiments of the present invention. For those of ordinary skill in the art, without departing from the inventive concept of the present invention, several modifications and improvements can be made, which all belong to the protection scope of the present invention.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202020373180.9U CN211895068U (en) | 2020-03-23 | 2020-03-23 | An automatic feeding mechanism for loading circuit boards and embryos in stacked trays |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202020373180.9U CN211895068U (en) | 2020-03-23 | 2020-03-23 | An automatic feeding mechanism for loading circuit boards and embryos in stacked trays |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN211895068U true CN211895068U (en) | 2020-11-10 |
Family
ID=73268755
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202020373180.9U Expired - Fee Related CN211895068U (en) | 2020-03-23 | 2020-03-23 | An automatic feeding mechanism for loading circuit boards and embryos in stacked trays |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN211895068U (en) |
Cited By (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111268420A (en) * | 2020-03-23 | 2020-06-12 | 昆山瑞宝达电子有限公司 | Automatic feeding mechanism for stacked charging tray loading circuit board and blank |
| CN112794018A (en) * | 2021-02-03 | 2021-05-14 | 深圳市联合东创科技有限公司 | Flexible circuit board automatic test production system |
| CN112816855A (en) * | 2021-02-03 | 2021-05-18 | 深圳市联合东创科技有限公司 | Double-flow water line type flexible circuit board test system |
| CN114030889A (en) * | 2021-12-09 | 2022-02-11 | 扬州京柏自动化科技有限公司 | Battery assembling machine |
| CN114056942A (en) * | 2021-11-19 | 2022-02-18 | 苏州浪潮智能科技有限公司 | Assembly equipment and feeding machine thereof |
| CN115159090A (en) * | 2022-07-12 | 2022-10-11 | 倍施力(厦门)智能装备有限公司 | A blade aligning machine |
| CN115488065A (en) * | 2022-11-21 | 2022-12-20 | 苏州鼎纳自动化技术有限公司 | Detection equipment |
-
2020
- 2020-03-23 CN CN202020373180.9U patent/CN211895068U/en not_active Expired - Fee Related
Cited By (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111268420A (en) * | 2020-03-23 | 2020-06-12 | 昆山瑞宝达电子有限公司 | Automatic feeding mechanism for stacked charging tray loading circuit board and blank |
| CN112794018A (en) * | 2021-02-03 | 2021-05-14 | 深圳市联合东创科技有限公司 | Flexible circuit board automatic test production system |
| CN112816855A (en) * | 2021-02-03 | 2021-05-18 | 深圳市联合东创科技有限公司 | Double-flow water line type flexible circuit board test system |
| CN112794018B (en) * | 2021-02-03 | 2025-04-15 | 深圳市联合东创科技有限公司 | Fully automatic test production system for flexible circuit boards |
| CN114056942A (en) * | 2021-11-19 | 2022-02-18 | 苏州浪潮智能科技有限公司 | Assembly equipment and feeding machine thereof |
| CN114030889A (en) * | 2021-12-09 | 2022-02-11 | 扬州京柏自动化科技有限公司 | Battery assembling machine |
| CN115159090A (en) * | 2022-07-12 | 2022-10-11 | 倍施力(厦门)智能装备有限公司 | A blade aligning machine |
| CN115488065A (en) * | 2022-11-21 | 2022-12-20 | 苏州鼎纳自动化技术有限公司 | Detection equipment |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111268420A (en) | Automatic feeding mechanism for stacked charging tray loading circuit board and blank | |
| WO2023071319A1 (en) | Stacked tray separating and feeding apparatus | |
| CN204528615U (en) | Battery automatic charging and material collecting device | |
| CN209051652U (en) | A blanking stacking mechanism | |
| CN105438841A (en) | Universal type automatic loading and unloading system of bottom tool separation method based on conveyor belt | |
| CN212944180U (en) | Automatic test equipment for electronic element | |
| CN105966924B (en) | TV backboard Palletizer | |
| CN210914300U (en) | An automatic feeding mechanism | |
| CN110510419A (en) | Tray type loading and unloading device | |
| CN115123815A (en) | Automatic feeding and discharging test equipment | |
| CN220097760U (en) | Full-automatic blanking machine for optical lenses | |
| CN109677912B (en) | Multi-layer board browning on-line board matching machine | |
| CN217263186U (en) | Flexible balance machine | |
| CN115083963A (en) | Chip sorting machine | |
| CN210709517U (en) | Automatic material rack storing and taking device for quartz crystal oscillator in vacuum chamber | |
| CN111278271A (en) | Automatic chip mounter that overturns of ceramic filter idiosome and PCB board | |
| CN115231057B (en) | Full-automatic bag opening machine | |
| CN211909556U (en) | A ceramic filter body and PCB board automatic flip placement machine | |
| CN212126691U (en) | Screen strorage device | |
| CN216955765U (en) | Appearance defect detection equipment | |
| CN211685779U (en) | boxed components | |
| CN116038270A (en) | A device for removing and dismantling material trays | |
| CN213386757U (en) | A tray dividing and transferring device and automatic loading and unloading equipment | |
| CN114113125A (en) | Appearance defect detection equipment and detection method thereof | |
| CN209684826U (en) | A kind of feeding device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20201110 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |