CN211597914U - Noise-reduction vehicle carrier - Google Patents
Noise-reduction vehicle carrier Download PDFInfo
- Publication number
- CN211597914U CN211597914U CN201921886403.5U CN201921886403U CN211597914U CN 211597914 U CN211597914 U CN 211597914U CN 201921886403 U CN201921886403 U CN 201921886403U CN 211597914 U CN211597914 U CN 211597914U
- Authority
- CN
- China
- Prior art keywords
- arm
- frame
- vehicle carrier
- clamping
- clamping arm
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 230000007246 mechanism Effects 0.000 claims description 10
- 230000033001 locomotion Effects 0.000 claims description 3
- 229910000831 Steel Inorganic materials 0.000 abstract description 4
- 239000010959 steel Substances 0.000 abstract description 4
- 230000032258 transport Effects 0.000 description 14
- 230000001360 synchronised effect Effects 0.000 description 12
- 239000003990 capacitor Substances 0.000 description 9
- 238000000034 method Methods 0.000 description 7
- 230000008569 process Effects 0.000 description 7
- 230000009471 action Effects 0.000 description 5
- 239000003381 stabilizer Substances 0.000 description 4
- 238000009434 installation Methods 0.000 description 3
- 238000013459 approach Methods 0.000 description 2
- 230000005540 biological transmission Effects 0.000 description 2
- 238000004891 communication Methods 0.000 description 2
- 230000000694 effects Effects 0.000 description 2
- NJPPVKZQTLUDBO-UHFFFAOYSA-N novaluron Chemical compound C1=C(Cl)C(OC(F)(F)C(OC(F)(F)F)F)=CC=C1NC(=O)NC(=O)C1=C(F)C=CC=C1F NJPPVKZQTLUDBO-UHFFFAOYSA-N 0.000 description 2
- 230000009467 reduction Effects 0.000 description 2
- 239000000969 carrier Substances 0.000 description 1
- 230000008859 change Effects 0.000 description 1
- 238000006243 chemical reaction Methods 0.000 description 1
- 230000008878 coupling Effects 0.000 description 1
- 238000010168 coupling process Methods 0.000 description 1
- 238000005859 coupling reaction Methods 0.000 description 1
- 238000006073 displacement reaction Methods 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 230000000149 penetrating effect Effects 0.000 description 1
Images






Landscapes
- Handcart (AREA)
Abstract
The application discloses a noise-reducing vehicle carrier, which comprises a rectangular frame, and a clamping arm system, a traveling system and a control system which are arranged on the frame, wherein the clamping arm system comprises two pairs of clamping arms, each clamping arm is independently provided with a clamping arm motor, each clamping arm is arranged on the frame through a vertical rotating shaft, and the clamping arms of the same pair have a folding state of being attached to the same side edge of the frame and a working state of being perpendicular to the side edge and enabling the two clamping arms to be arranged side by side; each clamping arm comprises a swinging seat connected with the vertical rotating shaft and an arm rod hinged on the swinging seat through a horizontal rotating shaft, and at least two auxiliary bearing rollers are arranged at one end of the arm rod far away from the vertical rotating shaft; for each arm rod, a carrier roller for supporting the arm rod and a supporting plate for bearing at least one auxiliary bearing roller are arranged on the frame. The application provides a vehicle carrier of making an uproar falls effectively suppresses the noise that produces when the arm lock moves, and need not increase the steel use amount of parking stall frame, reduces parking stall frame cost.
Description
Technical Field
The application relates to the technical field of stereo garages, in particular to a noise-reducing vehicle carrier.
Background
The stereo garage is the main equipment that solves city parking difficulty at present, and after solving the parking problem, people also have higher and higher noise and the quality requirement to the stereo garage. The vehicle carrier is one of the core devices of the whole garage with high-frequency action, one of the main noises is generated by the action of clamping arms in receiving and releasing, in order to solve the problem, at present, only the steel structure part where the clamping arms of the vehicle carrier are located is implemented, and the steel structure part also comprises a large number of parking space frames, so that the cost is increased, the noise reduction effect is not obvious, the actions of receiving and releasing the clamping arms are too high, the damage of rollers on the clamping arms is serious, and the garage fault rate is correspondingly increased.
SUMMERY OF THE UTILITY MODEL
In order to solve the noise problem of vehicle carrier, this application provides a vehicle carrier of making an uproar falls, reduces the noise, reduces the parking stall frame cost.
A noise-reducing vehicle carrier comprises a rectangular frame, a clamping arm system, a traveling system and a control system, wherein the clamping arm system, the traveling system and the control system are arranged on the frame, the clamping arm system comprises two pairs of clamping arms and a clamping arm motor for driving the clamping arms to clamp and fold, each clamping arm is arranged on the frame through a vertical rotating shaft, and each pair of clamping arms has a folding state attached to the same side edge of the frame and a working state perpendicular to the side edge and the two clamping arms are arranged side by side;
each clamping arm comprises a swinging seat connected with the vertical rotating shaft and an arm rod hinged on the swinging seat through a horizontal rotating shaft, and at least two auxiliary bearing rollers are arranged at one end of the arm rod far away from the vertical rotating shaft;
for each arm rod, a carrier roller for supporting the arm rod and a supporting plate for bearing at least one auxiliary bearing roller are arranged on the frame.
Several alternatives are provided below, but not as an additional limitation to the above general solution, but merely as a further addition or preference, each alternative being combinable individually for the above general solution or among several alternatives without technical or logical contradictions.
Optionally, a lightening hole extending along the length direction of the arm rod is formed in the arm rod, and the carrier roller corresponds to the position of the lightening hole in the folded state of the clamping arm.
Optionally, the lightening hole is located in the middle of the arm rod in the length direction, and the carrier roller corresponds to the middle of the lightening hole in the length direction.
Optionally, the at least one auxiliary load bearing roller corresponds to the pallet in the collapsed state of the clamp arm.
Optionally, the idler is mounted on a side edge of the frame by a support, the support includes a connecting portion fixedly connected with the frame and a support portion extending to below the arm, and the idler is rotatably mounted on the support portion.
Optionally, the pallet is mounted on the side edge of the frame, the bottom surface of the pallet is a plane matched with the supporting surface, and the edge of the top surface of the pallet is provided with a guide surface 10a for guiding the auxiliary bearing roller to gradually approach the ground.
Optionally, the pallet carries an auxiliary load bearing roller furthest from the vertical axis of rotation.
Optionally, the supporting plate extends along the motion track of the auxiliary bearing roller and at least extends to a state that the supporting roller is separated from the arm rod and still bears the auxiliary bearing roller.
Optionally, the opposite side of the arm rod of the same pair of clamping arms in the working state is a working edge contacted with the wheel, and each arm rod is provided with a rotating roller contacted and matched with the wheel at the working edge.
Optionally, each of the clamp arms is provided with a clamp arm motor, the mounting position of each clamp arm motor is located at the edge of the frame body on the side where the driven clamp arm is located, and the spindle of each clamp arm motor is arranged along the advancing direction of the frame body and is linked with the corresponding clamp arm through a worm and gear mechanism.
The application provides a vehicle carrier of making an uproar falls, simple structure, simple to operate effectively suppresses the noise that produces when the arm lock moves, and need not increase the steel use amount of parking stall frame, reduces parking stall frame cost.
Drawings
Fig. 1 is a schematic view of a stereo garage handling system;
FIG. 2a is a top view of the vehicle carrier of the present application in an operational position;
FIG. 2b is a top view of the vehicle carrier shown in the collapsed position;
FIG. 3 is a schematic view of the operating state of the clamp arm system in the vehicle carrier of the present application;
FIG. 4 is a schematic view of a clamping arm system of the present application in a collapsed state;
FIG. 5 is a schematic view of a drive unit in a vehicle carrier according to the present application;
FIG. 6a is a schematic view of a tensioning mechanism in a vehicle carrier of the present application (in one of its states);
FIG. 6b is a schematic view of the tensioning mechanism in the vehicle carrier of the present application (another state);
FIG. 7 is a schematic view of the installation of a supercapacitor in a vehicle carrier according to the present application;
FIG. 8 is a schematic view of the present application showing the engagement of a vehicle carrier with a rail;
FIG. 9a is a schematic view of the power controller installation in the vehicle carrier of the present application;
FIG. 9b is a cross-sectional view taken along line A-A of FIG. 9 a;
FIG. 10 is a schematic view of the voltage regulator installation in the vehicle carrier of the present application;
FIG. 11 is a side view of the present application vehicle carrier;
FIG. 12 is a side view of an arm of the present application vehicle carrier;
FIG. 13 is a top view of an arm of the present vehicle carrier;
FIG. 14 is a view from the direction B of FIG. 12;
FIG. 15 is a top view of a support frame and spindle of the vehicle carrier of the present application;
FIG. 16 is a partial cross-sectional view of a carrier and spindle for a vehicle carrier according to the present application;
FIG. 17 is a schematic view illustrating a first process of switching the clamp arms of the vehicle carrier from the folded state to the working state according to the present application;
FIG. 18 is a schematic view of a second process for switching the gripper arms of the vehicle carrier from the folded state to the working state according to the present application;
FIG. 19a is a top view of a pallet in the vehicle carrier of the present application;
FIG. 19b is a side view of a pallet in the vehicle carrier of the present application;
FIG. 20a is a top view of an idler and pedestal of the vehicle carrier of the present application;
FIG. 20b is a side view of an idler and pedestal of the vehicle carrier of the present application;
fig. 21 is a schematic view of the communication principle of the garage handling system.
In the figure: 1. a vertical transport device; 2. a horizontal transport device; 3. a vehicle carrier; 4. a frame; 5. clamping arms; 51. lightening holes; 52. a rotating roller; 53. a clamp arm motor; 54. an arm lever; 55. a vertical rotating shaft; 56. a swing seat; 57. a worm; 6. a drive unit; 61. a traveling motor; 62. a driving wheel; 63. a synchronous sprocket; 64. adjusting a rod; 65. a synchronization chain; 66. tensioning the shaft; 67. a tension sprocket; 7. a driven wheel; 8. auxiliary load-bearing rollers; 9. a carrier roller; 10. a support plate; 10a, a guide surface 10 a; 11. a super capacitor; 12. a support plate; 12a, side walls 12 a; 13. a guide roller; 14. a guide rail; 15. a power supply controller; 16a, a vertical portion 16 a; 16b, a horizontal portion 16 b; 17. a support frame; 18. a voltage regulator; 19. a support; 20. and (4) a support.
Detailed Description
The technical solutions in the embodiments of the present application will be clearly and completely described below with reference to the drawings in the embodiments of the present application, and it is obvious that the described embodiments are only a part of the embodiments of the present application, and not all of the embodiments. All other embodiments, which can be derived by a person skilled in the art from the embodiments given herein without making any creative effort, shall fall within the protection scope of the present application.
For a better description and illustration of embodiments of the application, reference may be made to one or more of the drawings, but additional details or examples used in describing the drawings should not be construed as limiting the scope of any of the inventive concepts of the present application, the presently described embodiments, or the preferred versions.
It will be understood that when an element is referred to as being "connected" to another element, it can be directly connected to the other element or intervening elements may also be present. When a component is referred to as being "disposed on" another component, it can be directly on the other component or intervening components may also be present.
Unless defined otherwise, all technical and scientific terms used herein have the same meaning as commonly understood by one of ordinary skill in the art to which this application belongs. The terminology used herein in the description of the present application is for the purpose of describing particular embodiments only and is not intended to be limiting of the application.
The vehicle carrier with good passing performance is used for transferring vehicles in the stereo garage, can also be applied to other occasions needing load carrying, and is described in detail below by taking one of the application occasions in the stereo garage as an example.
Referring to fig. 1, the stereo garage handling system includes: a vertical transportation device 1 that transports the vehicle in the vertical direction, a horizontal transportation device 2 that transports the vehicle in the horizontal direction, and a vehicle carrier 3 that transfers the vehicle.
The vehicle carriers 3 are two, one is a master vehicle carrier 3, the other is a slave vehicle carrier 3, the structures of the master vehicle carrier 3 and the slave vehicle carrier 3 are basically the same, and the master vehicle carrier 3 and the slave vehicle carrier 3 respectively carry the front wheels and the rear wheels of the vehicle to jointly complete the transportation of the vehicle.
When parking, the vehicle carrier 3 transfers the vehicle from the garage entrance to the vertical transportation device 1, after the vertical transportation device 1 transports the vehicle to the corresponding floor height, the vehicle carrier 3 transfers the vehicle to the horizontal transportation device 2, the horizontal transportation device 2 transports the vehicle to the corresponding parking space entrance, the vehicle carrier 3 transfers the vehicle to the corresponding parking space, and when taking the vehicle, the process is reversed.
Referring to fig. 2a and 2b, a noise-reduced vehicle carrier comprises a rectangular frame 4, and a clamping arm system, a traveling system and a control system which are mounted on the frame 4, wherein the clamping arm system comprises two pairs of clamping arms 5, each clamping arm 5 is individually configured with a clamping arm motor 53, each clamping arm 5 is mounted on the frame 4 through a vertical rotating shaft 55, and the same pair of clamping arms 5 has a folding state of being attached to the same side of the frame 4 and a working state of being perpendicular to the side and arranging the two clamping arms 5 side by side;
each clamping arm 5 comprises a swinging seat 56 connected with a vertical rotating shaft 55 and an arm rod 54 hinged on the swinging seat 56 through a horizontal rotating shaft, and at least two auxiliary bearing rollers 8 are arranged at one end of the arm rod 54 far away from the vertical rotating shaft 55;
for each arm 54, a carrier roller 9 for supporting the arm 54 and a pallet 10 carrying at least one auxiliary bearing roller 8 are mounted on the frame 4.
In the process of switching the clamping arm 5 from the folding state to the working state, the following actions are sequentially included:
referring to fig. 2b, in the collapsed state, the support roller 9 supports the arm 54, and the pallet 10 supports the auxiliary load-bearing roller 8;
as shown in fig. 17, the supporting rollers 9 rotate and gradually disengage from the lightening holes 51, and the supporting plate 10 still supports the auxiliary bearing rollers 8;
as shown in fig. 18, the auxiliary load bearing rollers 8 gradually disengage from the pallet 10 and slightly land.
The carrier roller 9 can rotate relative to the lightening hole 51, and the auxiliary bearing roller 8 can rotate relative to the supporting plate 10, so that the clamping arm 5 can move more stably in the switching process of the folding state and the working state.
Referring to fig. 11, when the clamping arm 5 is folded, the auxiliary bearing roller 8 does not contact with the ground, and when the clamping arm 5 is in a working state, the auxiliary bearing roller 8 contacts with the ground, therefore, in the process of switching the clamping arm 5 from the folded state to the working state, the auxiliary bearing roller 8 has a certain displacement in the height direction, and through the bearing effect of the carrier rollers 9 and the supporting plate 10, the auxiliary bearing roller 8 drops in the height direction in a segmented manner, so that the noise generated by the direct collision of the auxiliary bearing roller 8 and the parking space frame is greatly reduced, and the user experience of the garage is improved.
In the folded state of the clamping arm 5, the supporting roller 9 corresponds to the position of the lightening hole 51 on the arm rod 54, and in the folded state of the clamping arm 5, at least one auxiliary bearing roller 8 corresponds to the position of the supporting plate 10.
Referring to fig. 2b, the lightening hole 51 is located in the middle of the arm rod 54 in the length direction, and the idler 9 corresponds to the middle of the lightening hole 51 in the length direction. Referring to fig. 17 and 18, the pallet 10 carries an auxiliary load bearing roller 8 furthest from the vertical axis of rotation 55.
As shown in fig. 20a and 20b, the idler 9 is mounted on the side edge of the frame 4 by means of a support 20, the support 20 comprising a connecting portion fixedly connected to the frame 4 and a support portion extending below the arm 54, on which the idler 9 is rotatably mounted.
Referring to fig. 19a and 19b, the pallet 10 is installed on the side edge of the frame 4, the bottom surface of the pallet 10 is a plane surface matching with the supporting surface, and the top surface edge of the pallet 10 has a guide surface 10a guiding the auxiliary load bearing roller 8 to gradually approach the ground.
Referring to fig. 17, the pallet 10 extends along the movement path of the auxiliary load bearing roller 8 at least until the auxiliary load bearing roller 8 is still supported in a state where the idler roller 9 is separated from the arm 54.
Vehicle carrier 3 transfers vehicles between vertical conveyance device 1 and horizontal conveyance device 2, vertical conveyance device 1 is located in a roadway, vertical conveyance device 1 and horizontal conveyance device 2 have a gap when they are located at the corresponding positions, and vehicle carrier 3 needs to span the gap when performing vehicle conveyance.
As shown in fig. 2a, 11, 12 and 13, the arm 54 is provided with at least two auxiliary load bearing rollers 8 at an end away from the vertical rotation shaft 55, and in the working state of the clamping arm 5, the auxiliary load bearing rollers 8 are arranged in sequence along the traveling direction of the vehicle carrier 3.
Each supplementary bearing gyro wheel 8 arranges in proper order along vehicle carrier 3's direction of travel, when locating through the clearance, supplementary bearing gyro wheel 8 loops through the clearance for the tip of armed lever 54 has the strong point all the time, avoids supplementary bearing gyro wheel 8 card in the clearance, guarantees the stability that vehicle carrier 3 used, prolongs supplementary bearing gyro wheel 8's life.
In order to accommodate a narrow width of the truck bed, the end of the arm 54 always has the auxiliary load bearing roller 8 to provide a support point to ensure the load bearing capacity of the clamp arm 5 and thus the vehicle carrier 3, despite the corresponding reduction in length of the arm 54.
The length of the arm 54 affects the width of the vehicle carrier 3 in the operating state, and the width of the arm 54 affects the width of the vehicle carrier 3 in the folded state, so that the length and width of the arm 54 are limited, and in order to fully utilize the size of the arm 54 for mounting the auxiliary load-bearing rollers 8, the auxiliary load-bearing rollers 8 are sequentially arranged in the direction perpendicular to the traveling direction of the vehicle carrier 3 in the operating state of the clamp arm 5.
In order to further increase the space efficiency, the projections of the auxiliary load bearing rollers 8 have a partial overlap in a plane perpendicular to the length direction of the arm 54, see fig. 14.
Referring to fig. 13, the rotating shafts of the auxiliary bearing rollers 8 are arranged in parallel, and the minimum gap between the rim of one auxiliary bearing roller 8 and the rotating shaft of the other auxiliary bearing roller 8 in two adjacent auxiliary bearing rollers 8 is 5-10 mm.
Referring to fig. 15 and 16, the rotating shaft of each auxiliary load bearing roller 8 is mounted on the arm rod 54 through a bracket 19, the bracket 19 is fixed at the end of the arm rod 54 through a bolt, and the rotating shaft is fixed on the bracket 19 through a bolt.
Referring to fig. 2a to 5, the middle of the frame 4 along the traveling direction is a power area, two pairs of clamp arms 5 are respectively arranged at two opposite sides of the frame 4 along the traveling direction, and the same pair of clamp arms 5 and corresponding clamp arm motors 53 are located at two sides of the power area; the walking system comprises: two sets of drive units 6 that are located the power zone and be located the driven wheel 7 in frame 4 four corners, every set of drive unit 6 includes: two driving wheels 62 arranged in sequence along the traveling direction, wherein the top of the rim of the driving wheel 62 is lower than that of the driven wheel 7; a walking motor 61 for driving one of the driving wheels 62 to rotate; a synchronizing mechanism for maintaining the two drive wheels 62 in synchronous rotation.
In this embodiment, the driving of each clamping arm 5 separately configured with the clamping arm motor 53 is taken as an example for description, and the clamping arm motor may also drive 2 clamping arms simultaneously, or the clamping arm motor directly drives 2 pairs of clamping arms simultaneously, and these two clamping arm motor driving modes are not described in this embodiment again.
The power area between the two pairs of clamping arms 5 is the area with the largest stress load, the driving unit 6 is arranged in the power area, the driving unit 6 is used for driving the frame 4 to advance, the force transmission through the frame 4 is avoided, the load born by the frame 4 is reduced, and the strength and the stability of the frame 4 are ensured.
The top point of the rim of the driving wheel 62 is lower than that of the rim of the driven wheel 7, so that the driving wheel 62 always keeps contact with the ground while providing enough bearing capacity, the friction force between the driving wheel 62 and the ground is kept, and the walking capacity of the vehicle carrier 3 is improved.
The rim vertex of the driving wheel 62 is lower than the rim vertex of the driven wheel 7, so that the limitation of the size of the driving wheel 62 on the thickness of the vehicle carrier 3 is reduced, and the length of the vehicle carrier 3 is not more than 2200mm, the width is not more than 820mm, and the height is not more than 90mm in a folded state of the clamping arms 5, so that the vehicles can freely shuttle.
The difference in height between the rim apex of the driving wheel 62 and the rim apex of the driven wheel 7 is at least 5 mm.
Referring to fig. 2a, the main shaft of the traveling motor 61 extends in a direction perpendicular to the traveling direction of the frame 4, the main shaft axes of the two traveling motors 61 are arranged in a staggered manner (i.e., the main shaft axes of the two traveling motors 61 are not collinear), and the main shaft output end of each traveling motor 61 faces the driving wheel 62 on the corresponding side.
The wheel shafts of the two driving wheels 62 are rotatably mounted on the frame 4 through bearings, the traveling motor 61 is fixed on a mounting plate, and the mounting plate is fixed on the frame 4 through bolts. The output shaft of the walking motor 61 is fixedly connected with the wheel shaft of one of the driving wheels 62 through a coupling.
Four driven wheels 7 are respectively arranged at four corners of the frame 4, wheel shafts of the driven wheels 7 are fixedly arranged on the frame 4, the driven wheels 7 are rotatably matched on the corresponding wheel shafts, and the rotation of the wheel shafts is limited by clamping plates fixed on the frame 4.
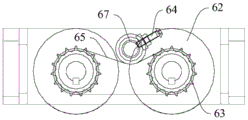
Referring to fig. 5, the synchronization mechanism of each set of drive units 6 includes: the two synchronous chain wheels 63, the synchronous chain 65 wound on the two synchronous chain wheels 63 and the tensioning mechanism for adjusting the tension degree of the synchronous chain 65, wherein each synchronous chain wheel 63 coaxially rotates with a corresponding driving wheel 62, and the two synchronous chain wheels 63 are arranged side by side.
Referring to fig. 5, 6a, 6b, the tensioning mechanism comprises: a tension shaft 66 which is in sliding fit with the frame 4, a tension chain wheel 67 which is rotatably sleeved on the tension shaft 66 and is matched with the synchronous chain 65, and an adjusting rod 64 which is arranged on the frame 4 and is used for pushing the tension shaft 66 to change the position.
The frame 4 is provided with a strip-shaped guide hole, and two ends of the tensioning shaft 66 respectively extend into the corresponding guide holes. The length direction of the guide hole is consistent with the axial direction of the adjusting rod 64, the frame 4 is provided with a mounting seat, and the adjusting rod 64 is a screw rod in threaded fit with the mounting seat. A lock nut is also threadedly engaged with the adjustment rod 64. Two adjusting rods 64 are respectively arranged and act on two ends of the tensioning shaft 66 so as to ensure that the chain wheels on the tensioning shaft 66 are well meshed with the synchronous chain 65 in the adjusting process.
Referring to fig. 6a and 6b, by adjusting the position of the adjusting rod 64, the tension degree of the synchronous chain 65 can be adjusted, the transmission efficiency is improved, and the synchronous rotation of the two driving wheels 62 is ensured.
The clamping arm system comprises four clamping arms 5, the four clamping arms 5 are divided into two pairs, the clamping arms 5 in the same pair are arranged on the same long side of the frame 4, each clamping arm 5 is installed on the frame 4 through a vertical rotating shaft 55, and each pair of clamping arms 5 clamps one wheel of the vehicle. The mounting position of each arm motor 53 is at the edge of the frame 4 on the side where the arm 5 is driven, and the spindle of each arm motor 53 is arranged in the traveling direction of the frame 4.
Referring to fig. 2a, the same pair of clamping arms 5 also has a working state perpendicular to the same long side and the two clamping arms 5 are arranged side by side; as shown in fig. 2b, the arms 5 of the same pair have a folded state against the same long side of the frame 4.
Referring to fig. 3 and 4, the clamping arm 5 includes a swing seat 56 connected to a vertical rotating shaft 55 and an arm rod 54 hinged to the swing seat 56 through a horizontal rotating shaft, and the arm rod 54 is provided with a lightening hole 51 extending along the length direction of the arm rod 54. The clamping arm motor 53 is linked with the corresponding clamping arm 5 through a worm gear 57 mechanism, gear teeth are arranged on the periphery of the swinging seat 56, the worm gear 57 mechanism comprises a worm 57 which is coaxially butted with a main shaft of the clamping arm motor 53, and a worm gear which is also used as the swinging seat 56, and the worm 57 is connected with the main shaft of the clamping arm motor 53 through a coupler.
The clamping arm motor 53 drives the worm 57 to rotate, the swinging seat 56 rotates around the vertical rotating shaft 55 along with the rotation of the worm 57, and the arm rod 54 hinged on the swinging seat 56 rotates to the working state shown in fig. 2a or the folding state shown in fig. 2 b.
Referring to fig. 2a and 2b, the opposite side of the arm 54 of the clamping arm 5 in the working state is a working edge contacting with the wheel, and each arm 54 is provided with a rotating roller 52 contacting and matching with the wheel at the working edge. Referring to fig. 14, the upper surface of the arm 54 is a curved surface corresponding to the outer circumference of the wheel, and the rotating roller 52 is rotatably installed at the lowest portion of the curved surface.
The frame 4 is also provided with a super capacitor 11 which is connected with the walking motor 61, the clamping arm motor 53 and the control system through circuits for power supply, and the super capacitor 11 is arranged on two sides of the power area.
The super capacitors 11 are divided into two groups which are respectively positioned at two sides of the power area, the super capacitors 11 in the same group are installed in two areas, and a wire groove arranged along the advancing direction of the frame 4 is arranged between the two areas.
Referring to fig. 7, the frame 4 is provided with support plates 12 arranged at intervals, and the supercapacitors 11 in each area are fixedly mounted on the corresponding support plates 12. The support plate 12 has side walls 12a arranged opposite to each other on both sides, and the support plate 12 is fixed to the frame 4 by bolts penetrating the side walls 12 a. The supercapacitors 11 of each area are located in the area enclosed by the side walls 12a of the support plate 12.
The super capacitors 11 are connected in series on a circuit, a voltage stabilizer 18 connected to an output end of the super capacitor 11 and a power controller 15 for managing the super capacitor 11 and the voltage stabilizer 18 are further arranged on the frame 4, and the super capacitor 11 supplies power to the traveling system through the voltage stabilizer 18. Referring to fig. 9a and 9b, a bracket is mounted on the frame 4, the bracket includes a horizontal portion 16b and a vertical portion 16a, the vertical portion 16a is fixed to the frame 4 by bolts, and the power controller 15 is fixed to the horizontal portion 16 b.
Referring to fig. 10, the frame 4 is provided with support frames 17 arranged at intervals, each support frame 17 includes a bottom plate and two side plates vertically arranged on the bottom plate and arranged oppositely, the two side plates are respectively fixed on the frame 4 by bolts, and the voltage stabilizer 18 is placed and fixed on the bottom plate.
Referring to fig. 8, a guide roller 13 is arranged at the bottom of the frame 4 of the vehicle carrier 3, the rotating shaft of the guide roller 13 is vertically arranged, and the vertical transportation device 1 and the horizontal transportation device 2 are provided with a guide rail 14 matched with the guide roller 13.
The communication principle of the horizontal transport device 2, the master vehicle carrier 3 and the slave vehicle carrier 3 is shown in fig. 21, a horizontal transport device controller and a wireless master station connected with the horizontal transport device controller are arranged on the horizontal transport device 2, and the horizontal transport device 2 communicates with a control system of the stereo garage.
The control system of each vehicle carrier 3 includes: the robot comprises a vehicle carrier controller, wireless slave stations which are connected with the vehicle carrier controller and are communicated with the wireless master station, traveling motor drivers which are connected with the vehicle carrier controller and are connected with the traveling motors 61 in a one-to-one correspondence mode, and clamping arm motor drivers which are connected with the vehicle carrier controller and are connected with the clamping arm motors 53 in a one-to-one correspondence mode.
The wireless master station and the wireless slave station are communicated by adopting industrial wireless Ethernet, and the wireless slave station and the vehicle carrier controller are connected by adopting Ethernet wired connection.
The vehicle carrier controller controls the corresponding traveling motor 61 and the clamping arm motor 53 to move and clamp the vehicle, and the actions between the master vehicle carrier 3 and the slave vehicle carrier 3 are coordinated by the horizontal transport device controller.
The slave vehicle carrier 3 differs from the master vehicle carrier 3 only in that the vehicle carrier controller of the slave vehicle carrier 3 is also connected with a distance measuring device that measures the distance of the slave vehicle carrier 3 from the master vehicle carrier 3 to provide a reference signal for the slave vehicle carrier 3 to adjust the position relative to the master vehicle carrier 3.
The handling of the vehicle with the vehicle handler 3 comprises the steps of:
when a vehicle enters the garage entrance, the vehicle profile data is captured by using the light curtain detected by the wheel profile, the wheel track data is obtained through the conversion of the stereo garage control system, and the wheel track data is fed back to the horizontal transport device 2 and fed back to the slave vehicle carrier 3 by the horizontal transport device 2;
after the wheel track data is obtained from the vehicle carrier 3, the distance between the vehicle carrier 3 and the main vehicle carrier is automatically adjusted according to the measuring result of the distance measuring device until the wheel track data is met;
the main vehicle carrier 3 and the auxiliary vehicle carrier 3 synchronously move to the bottom of the vehicle, and the corresponding vehicle is clamped through respective clamping arm systems to carry the vehicle;
the master vehicle carrier 3 and the slave vehicle carrier 3 travel the carrier vehicle to the designated position in synchronization.
The technical features of the embodiments described above may be arbitrarily combined, and for the sake of brevity, all possible combinations of the technical features in the embodiments described above are not described, but should be considered as being within the scope of the present specification as long as there is no contradiction between the combinations of the technical features.
The above-mentioned embodiments only express several embodiments of the present application, and the description thereof is more specific and detailed, but not construed as limiting the scope of the utility model. It should be noted that, for a person skilled in the art, several variations and modifications can be made without departing from the concept of the present application, which falls within the scope of protection of the present application. Therefore, the protection scope of the present patent shall be subject to the appended claims.
Claims (10)
1. The utility model provides a vehicle carrier of making an uproar falls, includes the frame of rectangle and installs arm lock system, traveling system and the control system on the frame, its characterized in that:
the clamping arm system comprises two pairs of clamping arms and a clamping arm motor for driving the clamping arms to clamp and fold, each clamping arm is arranged on the frame through a vertical rotating shaft, and each pair of clamping arms has a folding state of being attached to the same side edge of the frame and a working state of being perpendicular to the side edge and enabling the two clamping arms to be arranged side by side;
each clamping arm comprises a swinging seat connected with the vertical rotating shaft and an arm rod hinged on the swinging seat through a horizontal rotating shaft, and at least two auxiliary bearing rollers are arranged at one end of the arm rod far away from the vertical rotating shaft;
for each arm rod, a carrier roller for supporting the arm rod and a supporting plate for bearing at least one auxiliary bearing roller are arranged on the frame.
2. The noise-reduced vehicle carrier as recited in claim 1, wherein the arm has lightening holes extending along a length of the arm, and the idler is positioned in correspondence with the lightening holes when the clamp arms are in the collapsed state.
3. The noise reduced vehicle carrier of claim 2, wherein the lightening holes are located at a middle portion of the arm in a length direction, and the carrier rollers correspond to the middle portion of the lightening holes in the length direction.
4. The noise-reduced vehicle carrier according to claim 1, wherein the at least one auxiliary load-bearing roller corresponds to the pallet in the collapsed state of the clamp arms.
5. The noise reduced vehicle carrier of claim 1, wherein the idler is mounted to a side edge of the frame by an abutment, the abutment including a connecting portion fixedly connected to the frame and a support portion extending below the arm, the idler being rotatably mounted on the support portion.
6. The noise reduced vehicle carrier as in claim 1, wherein said pallet is mounted on the side edges of the frame, the bottom surface of said pallet being a flat surface that mates with the support surface, the top surface edge of said pallet having guide surfaces 10a that guide the auxiliary load bearing rollers progressively closer to the ground.
7. The noise reduced vehicle carrier of claim 1, wherein said pallet carries an auxiliary load bearing roller furthest from the vertical axis of rotation.
8. The noise reduced vehicle carrier of claim 1, wherein the pallet extends along the path of movement of the auxiliary load bearing roller at least until the idler is disengaged from the arm and still carries the auxiliary load bearing roller.
9. The noise-reduced vehicle carrier as recited in any one of claims 1-8, wherein the opposite side of the arms of the same pair of arms in the working state is a working edge in contact with the wheel, and each arm is provided with a rotating roller in contact with and engaged with the wheel at the working edge.
10. The noise-reduced vehicle carrier according to any one of claims 1 to 8, wherein each clamping arm is provided with a clamping arm motor, the mounting position of each clamping arm motor is located at the edge of the frame body on the side where the driven clamping arm is located, and the spindle of each clamping arm motor is arranged along the traveling direction of the frame body and is linked with the corresponding clamping arm through a worm and gear mechanism.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201921886403.5U CN211597914U (en) | 2019-11-04 | 2019-11-04 | Noise-reduction vehicle carrier |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201921886403.5U CN211597914U (en) | 2019-11-04 | 2019-11-04 | Noise-reduction vehicle carrier |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN211597914U true CN211597914U (en) | 2020-09-29 |
Family
ID=72587065
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201921886403.5U Active CN211597914U (en) | 2019-11-04 | 2019-11-04 | Noise-reduction vehicle carrier |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN211597914U (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110886523A (en) * | 2019-11-04 | 2020-03-17 | 杭州西子智能停车股份有限公司 | A noise-reducing vehicle carrier |
-
2019
- 2019-11-04 CN CN201921886403.5U patent/CN211597914U/en active Active
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110886523A (en) * | 2019-11-04 | 2020-03-17 | 杭州西子智能停车股份有限公司 | A noise-reducing vehicle carrier |
| CN110886523B (en) * | 2019-11-04 | 2025-02-18 | 杭州西子智能停车股份有限公司 | Vehicle transporter with noise reduction |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110700663B (en) | AGV trolley-based vehicle parking method | |
| CN211032326U (en) | AGV floor truck | |
| WO2019096288A1 (en) | Split-type manipulator and method for carrying vehicle using same | |
| CN104120906B (en) | Multi-storied garage intelligent floor truck | |
| CN211597913U (en) | Vehicle carrier with good trafficability characteristic | |
| CN116118673A (en) | Module type double-side heavy truck power exchange station | |
| CN211396838U (en) | Vehicle carrier | |
| CN110886522A (en) | a vehicle carrier | |
| CN110886523B (en) | Vehicle transporter with noise reduction | |
| CN209908048U (en) | Vertical circulation stereo garage with anti-shaking function | |
| CN110424794B (en) | Vehicle carrying device with telescopic comb support and stereo garage | |
| CN103466444B (en) | Crane trolley | |
| KR20140126127A (en) | Battery Charging Personal Mono Rail System | |
| CN101391696A (en) | Telescopic rolling bed | |
| CN211499978U (en) | Vehicle position adjusting device, lift and stereo garage | |
| CN110886524B (en) | A vehicle transporter with good passability | |
| CN112727207B (en) | A single-motor gear-driven outer-clamping carrier for large tires and using method | |
| CN218912413U (en) | Double round actuating mechanism, sideslip car and stereo garage for stereo garage | |
| CN204799649U (en) | Running gear of photovoltaic array clean robot | |
| CN214290078U (en) | Guide rail moving device of aluminum tractor | |
| CN208486180U (en) | A kind of material transport and hanging basket system for bridge construction | |
| CN115234062B (en) | A method of using a shuttle gear-driven external clamp-type carrier | |
| CN223327549U (en) | Conveyer suitable for processing of automotive interior non-woven fabrics | |
| CN223547035U (en) | Parallel annular production line for bicycle assembling line | |
| CN222282647U (en) | A wiring device for lithium battery plant construction |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |