CN211444763U - A tower crane installation intelligent alignment navigation system - Google Patents
A tower crane installation intelligent alignment navigation system Download PDFInfo
- Publication number
- CN211444763U CN211444763U CN201922186106.6U CN201922186106U CN211444763U CN 211444763 U CN211444763 U CN 211444763U CN 201922186106 U CN201922186106 U CN 201922186106U CN 211444763 U CN211444763 U CN 211444763U
- Authority
- CN
- China
- Prior art keywords
- alignment
- installation
- tower crane
- satellite positioning
- station
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images




Landscapes
- Radio Relay Systems (AREA)
Abstract
一种塔机安装智能对位导航系统,包括卫星定位固定基站、安装对位基准站、安装对位移动站、吊装监护仪。卫星定位固定基站将定位数据发送到安装对位基准站、安装对位移动站;安装对位基准站与卫星定位固定基站交互通讯修正安装对位基准站的坐标精度,安装对位基准站将坐标信息发送至吊装监护仪、现场调度指挥平台;安装对位移动站与卫星定位固定基站交互通讯修正安装对位移动站的坐标精度及对地面的高度,安装对位移动站将坐标信息及对地面的高度信息发送至吊装监护仪、现场调度指挥平台。吊装监护仪分别与云平台、现场调度指挥平台通讯连接,云平台与手机APP连接。本实用新型系统可以有效提高塔机安装效率,确保塔机安装过程中的安全性。

An intelligent alignment navigation system for tower crane installation includes a fixed base station for satellite positioning, an alignment reference station, a mobile alignment station, and a hoisting monitor. The satellite positioning fixed base station sends the positioning data to the installation alignment base station and the installation alignment mobile station; the installation alignment base station communicates with the satellite positioning fixed base station to correct the coordinate accuracy of the installation alignment base station, and the installation alignment base station converts the coordinates The information is sent to the hoisting monitor and the on-site dispatch command platform; the installation and alignment mobile station interacts with the satellite positioning fixed base station to correct the coordinate accuracy of the installation alignment mobile station and the height to the ground, and the installation alignment mobile station transfers the coordinate information to the ground. The height information is sent to the hoisting monitor and the on-site dispatch command platform. The hoisting monitor is connected to the cloud platform and the on-site dispatch command platform respectively, and the cloud platform is connected to the mobile APP. The system of the utility model can effectively improve the tower crane installation efficiency and ensure the safety in the tower crane installation process.
Description
技术领域technical field
本实用新型涉及塔机安装监护技术领域,具体涉及一种塔机安装智能导航对位系统。The utility model relates to the technical field of tower crane installation monitoring, in particular to an intelligent navigation alignment system for tower crane installation.
背景技术Background technique
目前我国塔机保有量约40万台,每年有大量塔机投入到建筑、安装项目上。但是塔机安装、拆除基本都是人工作业,整个作业过程只有人的监护,由于人的随意性及内外原因影响很容易导致塔机安装、拆除各环节发生不规范操作,为塔机安装、拆除埋下安全隐患,从而发生各种各样的安全事故。目前监管部门对塔机安全生产高度重视,出台了很多相关管理制度及规定。各相关单位领导也高度重视塔机安装、拆卸及顶升(加节、降节)作业安全,制定了一系列管理规程、规范。但是因为塔机体型庞大,吨位重,安装、拆除工作人员无法控制。现有技术中由于采用了汽车吊吊运、以及人工用拉绳对位等,参与对位的人无法掌握拉绳力度,导致在实际操作过程中一是对位速度慢,工效低,同时因为操作不当就可能发生重大安全事故。At present, there are about 400,000 tower cranes in my country, and a large number of tower cranes are invested in construction and installation projects every year. However, the installation and dismantling of tower cranes are basically manual operations, and the entire operation process is only under the supervision of people. Due to the randomness of people and the influence of internal and external reasons, it is easy to cause irregular operations in the installation and dismantling of tower cranes. Demolition and buried safety hazards, resulting in a variety of safety accidents. At present, the supervision department attaches great importance to the safe production of tower cranes, and has issued many relevant management systems and regulations. Leaders of relevant units also attach great importance to the safety of tower crane installation, disassembly and jacking (adding and lowering), and have formulated a series of management regulations and specifications. However, due to the huge size and heavy tonnage of the tower body, the installation and dismantling staff cannot control it. In the prior art, due to the use of car hoisting and manual alignment with a rope, the person participating in the alignment cannot grasp the strength of the rope, resulting in slow alignment speed and low work efficiency in the actual operation process. Improper operation may cause major safety accidents.
目前市面上未有塔机安装对位智能导航监护设备,有鉴于此,函待需要一种塔机安全安装、高效对位,提高施工效率的有效工具。At present, there is no tower crane installed with intelligent navigation monitoring equipment on the market. In view of this, there is a need for an effective tool for safe installation, efficient alignment of tower cranes and improving construction efficiency.
发明内容SUMMARY OF THE INVENTION
本实用新型提供一种塔机安装智能导航对位系统,可以有效提高塔机安装效率,确保塔机安装过程中的安全性。The utility model provides an intelligent navigation alignment system for tower crane installation, which can effectively improve the tower crane installation efficiency and ensure the safety in the tower crane installation process.
本实用新型采取的技术方案为:The technical scheme adopted by the utility model is:
一种塔机安装智能导航对位系统,包括卫星定位固定基站、安装对位基准站、安装对位移动站、吊装监护仪、云平台、现场调度指挥平台。An intelligent navigation and alignment system for tower crane installation includes a fixed base station for satellite positioning, a base station for alignment, a mobile station for alignment, a hoisting monitor, a cloud platform, and an on-site dispatch command platform.
所述卫星定位固定基站,用于获取定位数据,并将定位数据发送到安装对位基准站、安装对位移动站;The satellite positioning fixed base station is used to obtain positioning data, and send the positioning data to the installation alignment reference station and the installation alignment mobile station;
所述安装对位基准站,用于计算其位置坐标,并与卫星定位固定基站交互通讯修正安装对位基准站的坐标精度,安装对位基准站将坐标信息发送至吊装监护仪、现场调度指挥平台;The installation alignment reference station is used to calculate its position coordinates, and communicate with the satellite positioning fixed base station to correct the coordinate accuracy of the installation alignment reference station. The installation alignment reference station sends the coordinate information to the hoisting monitor and on-site dispatch command. platform;
所述安装对位移动站,用于计算其位置坐标及对地面的高度,并与卫星定位固定基站交互通讯修正安装对位移动站的坐标精度及对地面的高度,安装对位移动站将坐标信息及对地面的高度信息发送至吊装监护仪、现场调度指挥平台;The installation and alignment mobile station is used to calculate its position coordinates and the height to the ground, and communicates with the satellite positioning fixed base station to correct the coordinate accuracy of the installation alignment mobile station and the height to the ground. The information and the height information on the ground are sent to the hoisting monitor and the on-site dispatch command platform;
所述吊装监护仪分别与云平台、现场调度指挥平台通讯连接,云平台与手机APP连接。The hoisting monitor is respectively connected with the cloud platform and the on-site dispatch command platform, and the cloud platform is connected with the mobile phone APP.
所述卫星定位固定基站包括第一卫星定位天线、第一数传电台;第一卫星定位天线、第一数传电台连接固定基站主机。The satellite positioning fixed base station includes a first satellite positioning antenna and a first digital radio station; the first satellite positioning antenna and the first digital radio station are connected to the fixed base station host.
所述塔机安装对位基准站包括第二卫星定位天线、第三卫星定位天线、第二数传电台;第二卫星定位天线、第三卫星定位天线、第二数传电台连接对位基准站主机,对位基准站主机、第一车载摄像机与第一交换机连接,第一交换机连接第一网桥。The tower crane installation alignment reference station includes a second satellite positioning antenna, a third satellite positioning antenna, and a second digital radio station; the second satellite positioning antenna, the third satellite positioning antenna, and the second digital radio station are connected to the alignment reference station The host, the host of the alignment base station, the first vehicle-mounted camera are connected to the first switch, and the first switch is connected to the first network bridge.
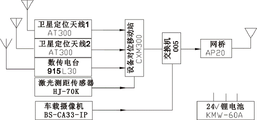
所述塔机安装对位移动站包括第四卫星定位天线、第五卫星定位天线、第三数传电台、激光测距传感器;第四卫星定位天线、第五卫星定位天线、第三数传电台、激光测距传感器连接对位移动站主机,对位移动站主机、第二车载摄像机与第二交换机连接,第二交换机连接第二网桥。The tower crane installation alignment mobile station includes a fourth satellite positioning antenna, a fifth satellite positioning antenna, a third digital radio station, and a laser ranging sensor; the fourth satellite positioning antenna, the fifth satellite positioning antenna, and the third digital radio station . The laser ranging sensor is connected to the host of the mobile station, the host of the mobile station, the second vehicle-mounted camera is connected to the second switch, and the second switch is connected to the second bridge.
所述塔机安装对位移动站还包括锂电池,锂电池连接对位移动站主机。The tower crane installation alignment mobile station also includes a lithium battery, and the lithium battery is connected to the alignment mobile station host.
所述吊装监护仪包括:The hoisting monitor includes:
车身水平传感器,用于检测车身水平度;Body level sensor for detecting body level;
支腿液压传感器,用于检测四个支腿压力;Outrigger hydraulic sensor for detecting the pressure of the four outriggers;
力矩限制器,用于检测力矩信号;Torque limiter, used to detect torque signal;
风速传感器,用于采集的风速信号;Wind speed sensor, used to collect wind speed signal;
所述车身水平传感器、支腿液压传感器、力矩限制器、风速传感器均连接监护仪主机,监护仪主机连接第三交换机,第三交换机连接4G通讯模块、4G通讯模块连接云平台。The body level sensor, the outrigger hydraulic sensor, the torque limiter and the wind speed sensor are all connected to the monitor host, the monitor host is connected to the third switch, the third switch is connected to the 4G communication module, and the 4G communication module is connected to the cloud platform.
所述吊装监护仪还包括:The hoisting monitor also includes:
脸谱识别传感器,用于采集维保人员、监督管理人员脸谱信息,脸谱识别传感器连接触摸屏,触摸屏连接第三交换机。The face recognition sensor is used to collect the face information of maintenance personnel and supervisors. The face recognition sensor is connected to the touch screen, and the touch screen is connected to the third switch.
所述吊装监护仪还包括:The hoisting monitor also includes:
IP对讲机、数传电台,所述IP对讲机、数传电台连接第三交换机,IP walkie-talkie, digital radio, the IP walkie-talkie and digital radio are connected to the third switch,
IP对讲机用于汽车吊司机与现场调度指挥平台通讯;数传电台用于与现场调度指挥平台通讯连接。The IP walkie-talkie is used for the communication between the truck crane driver and the on-site dispatch and command platform; the digital radio is used for the communication connection with the on-site dispatch and command platform.
所述吊装监护仪还包括:The hoisting monitor also includes:
半球摄像机,用于监控司机工作,Dome camera for monitoring driver work,
监控摄像机,用于监控吊钩工作,Surveillance cameras for monitoring hook work,
所述半球摄像机、监控摄像机连接录像机,录像机连接显示器,录像机连接第三交换机,第三交换机连接网桥。The dome camera and the monitoring camera are connected to a video recorder, the video recorder is connected to a display, the video recorder is connected to a third switch, and the third switch is connected to a network bridge.
所述现场调度指挥平台包括:The on-site dispatch command platform includes:
扫描仪、激光打印机,所述扫描仪、激光打印机连接笔记本电脑;A scanner and a laser printer, the scanner and the laser printer are connected to a notebook computer;
对讲指挥机、全站仪,所述对讲指挥机、全站仪连接第三交换机;The intercom commander and the total station, the intercom commander and the total station are connected to the third switch;
所述第三交换机连接笔记本电脑,笔记本电脑通过网络连接云平台。The third switch is connected to the notebook computer, and the notebook computer is connected to the cloud platform through the network.
本实用新型一种塔机安装智能导航对位系统,技术效果如下:The utility model is a tower crane installation intelligent navigation alignment system, and the technical effects are as follows:
1:利用卫星定位及激光测距技术实现了可视化塔机安装时按照标准节、平衡臂、起重臂的三维(水平对位及高度对位)立体数字化对位;从而有效提高塔机安装及指挥工作效率;1: Using satellite positioning and laser ranging technology to realize the three-dimensional (horizontal alignment and height alignment) three-dimensional digital alignment of the standard section, balance arm and boom during the installation of the visualized tower crane; thus effectively improving the installation and operation of the tower crane. Command work efficiency;
2:利用卫星定位技术,建立以塔身中心距为圆心的动态安全防护圈,实现了塔机平衡臂、起重臂吊装过程中的动态防碰撞;2: Using satellite positioning technology, establish a dynamic safety protection ring with the center distance of the tower body as the center, and realize the dynamic anti-collision during the hoisting process of the tower crane balance arm and boom;
3:利用流程监控管理技术,确保了每一道吊装工序的有序实施及科学管理;3: The use of process monitoring and management technology ensures the orderly implementation and scientific management of each hoisting process;
4:实现了现场监控与平台监控的“双保险”,现场司机通过触摸屏及显示器对每一道工序吊装进行数字化监控和视频监控,现场调度指挥人员、管理人员通过【塔机无忧吊装网】云平台及现场视频实现了全程数字化监控及视频监控,如果发现现场吊装操作或者安全任何一项有问题时就可以及时对其进行干预,确保吊装安全及高效;4: The "double insurance" of on-site monitoring and platform monitoring is realized. The on-site driver conducts digital monitoring and video monitoring of each process hoisting through the touch screen and display. The platform and on-site video have realized the whole process of digital monitoring and video monitoring. If any problem with on-site hoisting operation or safety is found, it can be intervened in time to ensure the safety and efficiency of hoisting;
5:实现了手机APP移动监控,塔机调度指挥或者管理人员可以通过手机APP在任何地方对塔机安装、拆除过程对进行远程监控。5: The mobile APP mobile monitoring is realized, and the tower crane dispatching commander or management personnel can remotely monitor the tower crane installation and dismantling process from anywhere through the mobile APP.
6:利用塔机安装对位移动站的卫星定位天线及激光测距传感器为塔机塔身、平衡臂、起重臂安装提供了移动坐标及高度对位信息,为塔身、平衡臂、起重臂安装对位计算创造了条件。6: Using the satellite positioning antenna and laser ranging sensor of the tower crane installation alignment mobile station to provide mobile coordinates and height alignment information for the tower crane tower body, balance arm, and boom installation, for the tower body, balance arm, lifting arm. The heavy arm installation alignment calculation creates conditions.
7:利用汽车吊对位监护仪的流程监控管理软件、安全防护软件及对位计算软件为塔机塔身、平衡臂、起重臂安装提供每一步流程监控及安全管理,确保每一步安装工艺质量符合标准要求。因为汽车吊吊装对位监护仪内部嵌入有安全管理软件,当汽车吊超力矩、车身倾斜超过规定要求、支腿失压、环境风速超过4级,平衡臂、起重臂安装时臂架距离离塔身太近,超过安全防护圈、塔臂吊装高度小于设定要求等系统都会自动报警、自动控制,确保塔机吊装安全;汽车吊吊装对位监护仪内部嵌入有对位计算软件,通过流程监控程序可以显示不同工序的塔身高度及性能特征,当塔机吊装的标准节或者平衡臂、起重臂等移动坐标出现后汽车吊吊装对位监护仪会自动计算移动坐标与目标坐标之间距离、高度等,为快速对位安装提供可视化导航安装服务,从而提高安装效率。7: Use the process monitoring management software, safety protection software and alignment calculation software of the car crane alignment monitor to provide each step process monitoring and safety management for the installation of the tower body, balance arm and boom to ensure the installation process of each step. The quality meets the standard requirements. Because the safety management software is embedded in the car hoisting alignment monitor, when the car hoist exceeds the torque, the body tilt exceeds the specified requirements, the outrigger loses pressure, and the ambient wind speed exceeds level 4, the distance between the boom and the boom when the balance arm and the jib are installed If the tower body is too close, the safety protection ring is exceeded, and the tower arm hoisting height is less than the set requirements, the system will automatically alarm and automatically control to ensure the safety of tower crane hoisting; the car hoisting hoisting alignment monitor is embedded with alignment calculation software, through the process The monitoring program can display the tower height and performance characteristics of different processes. When the standard section of tower crane hoisting or the moving coordinates such as balance arm and jib appear, the alignment monitor will automatically calculate the distance between the moving coordinates and the target coordinates. Distance, height, etc., provide visual navigation installation services for quick alignment installation, thereby improving installation efficiency.
8:将现场安装实时监控与网络平台监控有机结合,实现了现场实施监控与现场调度指挥平台、管理人员二道实时监控,确保每一道安装工序符合标准及安全要求,同时由于现场调度指挥平台安装了GPS/4G通讯模块,为塔机无忧吊装网络云平台提供了位置GPS坐标,塔机无忧吊装网络云平台可以依据该塔机所在位置,实时提供辅助信息(比如:天气预报及当地地质特征)及注意事项等,为现场调度指挥提供更全面服务,确保塔机安装、拆除安全高效。8: The on-site installation real-time monitoring and network platform monitoring are organically combined to realize the two real-time monitoring of on-site implementation monitoring, on-site dispatching command platform, and management personnel to ensure that each installation process meets the standards and safety requirements. The GPS/4G communication module provides the location GPS coordinates for the tower crane worry-free hoisting network cloud platform. The tower crane worry-free hoisting network cloud platform can provide auxiliary information in real time according to the location of the tower crane (such as weather forecast and local geology). Features) and precautions, etc., to provide more comprehensive services for on-site dispatch and command to ensure safe and efficient tower crane installation and dismantling.
9:现场调度指挥及管理人员提供手机APP远程监控,手机APP与塔机无忧吊装网络云平台连接,现场调度指挥及管理人员可以通过手机APP在任意地方对塔机吊装进行远程监控、远程查询服务。9: On-site dispatch command and management personnel provide mobile APP remote monitoring. The mobile APP is connected to the tower crane worry-free hoisting network cloud platform. The on-site dispatch command and management personnel can remotely monitor and query the tower crane hoisting anywhere through the mobile APP. Serve.
附图说明Description of drawings
图1为本实用新型系统的原理示意图。FIG. 1 is a schematic diagram of the principle of the system of the present invention.
图2为本实用新型系统的卫星定位固定基站工作原理示意图。FIG. 2 is a schematic diagram of the working principle of the satellite positioning fixed base station of the system of the present invention.
图3为本实用新型系统的塔机安装对位基准站工作原理示意图。3 is a schematic diagram of the working principle of the tower crane installation alignment reference station of the system of the present invention.
图4为本实用新型系统的塔机安装对位移动站工作原理示意图。4 is a schematic diagram of the working principle of the tower crane installation alignment mobile station of the system of the present invention.
图5为本实用新型系统的吊装监护仪工作原理图;Fig. 5 is the working principle diagram of the hoisting monitor of the utility model system;
图6为本实用新型系统的吊装监护仪的视频监控部分工作原理图。FIG. 6 is a working principle diagram of the video monitoring part of the hoisting monitor of the system of the present invention.
图7为本实用新型系统的现场调度指挥平台工作原理图。Fig. 7 is the working principle diagram of the on-site dispatch command platform of the system of the present invention.
图8为本实用新型系统的塔机吊装工艺实施步骤流程示意图。FIG. 8 is a schematic flowchart of the implementation steps of the tower crane hoisting process of the system of the present invention.
具体实施方式Detailed ways
一种塔机安装智能导航对位系统,其组成和工作原理如图1~图7所示:A tower crane installation intelligent navigation alignment system, its composition and working principle are shown in Figures 1 to 7:
本实用新型系统主要由卫星定位固定基站、塔机安装对位基准站、塔机安装对位移动站、嵌入式空间数据算法系统、嵌入式吊装流程监控管理系统、汽车吊装监护仪、塔机无忧吊装网云平台、现场调度指挥平台等构成。系统架构如图1所示。The system of the utility model mainly consists of a satellite positioning fixed base station, a tower crane installation alignment reference station, a tower crane installation alignment mobile station, an embedded spatial data algorithm system, an embedded hoisting process monitoring and management system, a car hoisting monitor, and a tower crane without It is composed of a cloud platform for hoisting and on-site dispatching and commanding. The system architecture is shown in Figure 1.
1:卫星定位固定基站:1: Satellite positioning fixed base station:
是给每台塔机安装对位基准站、移动站提供差分数据,是整个系统的对位精度核心控制部分。其工作原理是:固定基站主机CXM300将自己通过第一卫星定位天线AT300,获取的高精度定位数据,通过第一数传电台915L30,将差分数据发送到塔机基座位置、或者塔机安装对位基准站、塔机安装对位移动站的接收机上;接收机通过将自身的定位数据和基准站的差分数据进行差分解算,最后得到厘米或者毫米级对位数据。卫星定位固定基站原理图如图2所示。It is to provide differential data for each tower crane installation alignment base station and mobile station, and it is the core control part of the alignment accuracy of the entire system. Its working principle is: the fixed base station host CXM300 sends the differential data to the base position of the tower crane, or the installation pair of the tower crane through the first digital radio station 915L30 through the high-precision positioning data obtained by itself through the first satellite positioning antenna AT300. The base station and tower crane are installed on the receiver of the mobile station for alignment; the receiver performs differential calculation between its own positioning data and the differential data of the base station, and finally obtains centimeter or millimeter level alignment data. The schematic diagram of the satellite positioning fixed base station is shown in Figure 2.
2:安装对位基准站:2: Install the alignment base station:
系统组成:它是由第二卫星定位天线AT300、第三卫星定位天线AT300,第二数传电台915L30,第一车载摄像机BS-CA33-IP,对位基准站主机CXM300,第一交换机005,第一网桥AP20等组成,原理图如图3所示。System composition: It consists of the second satellite positioning antenna AT300, the third satellite positioning antenna AT300, the second digital radio station 915L30, the first vehicle camera BS-CA33-IP, the alignment reference station host CXM300, the
工作时,对位基准站主机CXM300会自动计算出两个卫星定位天线AT300的位置坐标,第二数传电台915L30会不断与卫星定位固定基站通讯,不断修正对位基准站主机CXM300的坐标精度,同时对位基准站主机CXM300会将两个卫星定位天线AT300坐标信息通过第一网桥AP20送给汽车吊装监护仪、以及现场调度指挥平台,为现场调度指挥平台指挥汽车吊吊装标准节提供目标位置。第一车载摄像机BS-CA33-IP在吊装平衡臂及起重臂时是负责监控移动耳与固定耳连接时的情况,便于司机及时调整臂架姿态,提高对接固定效率。When working, the host CXM300 of the alignment base station will automatically calculate the position coordinates of the two satellite positioning antennas AT300, and the second digital radio 915L30 will continuously communicate with the fixed base station for satellite positioning to continuously correct the coordinate accuracy of the host of the alignment base station CXM300. At the same time, the host CXM300 of the alignment base station will send the coordinate information of the two satellite positioning antennas AT300 to the car hoisting monitor and the on-site dispatching command platform through the first network bridge AP20, so as to provide the target position for the on-site dispatching command platform to command the standard section of the car hoisting and hoisting. . The first vehicle-mounted camera BS-CA33-IP is responsible for monitoring the connection between the mobile ear and the fixed ear when hoisting the balance arm and the jib, which is convenient for the driver to adjust the boom posture in time and improve the docking and fixing efficiency.
实现过程如下:The implementation process is as follows:
按照塔机安装流程,在塔机基座符合标准要求条件下,首先要安装塔机基础节,当基础节安装好以后,就可以将安装对位基准站的第二、三卫星定位天线AT300按照说明书要求固定在基础节两边横撑中心轴线上,同时将激光测距传感器反射板安装说明书要求与卫星定位天线成90度安装在基础节横撑中心线上,然后与对位基准站主机CXM300系统连接,接通电源,开始工作。由于每一道工序尺寸不一样,空间算法也会有所差别,直到塔帽安装到位,安装对位基准站就不会移动。但是当塔身、塔帽安装就位后,就要将安装对位基准站移至回转塔架上,将第二、三卫星定位天线AT300与平衡臂成水平线安装在回转塔架中心轴线上,然后,将第一车载摄像机BS-CA33-IP安装在塔帽靠平衡臂安装方向,摄像机头部对准平衡臂与回转台结合部,为安装平衡臂提供视频支持;第一车载摄像机BS-CA33-IP安装到位后,再将激光测距传感器反射板安装在平衡臂方向套架外侧中心线上3M处,准备接收反射激光测距信号;然后固定好对位基准站主机CXM300,将第二、三卫星定位天线AT300与对位基准站主机CXM300连接,无误后开主机电源,此时,对位基准站主机CXM300会自动计算出主机第二、三卫星定位天线AT300的位置坐标,并且将2个坐标信息通过第一网桥AP20送给汽车吊吊装监护仪、及现场调度指挥平台,为汽车吊吊装标准节提供目标位置数据,为现场调度指挥平台指挥汽车吊吊装标准节提供目标位置数据。当平衡臂安装就位后按照程序要求将平衡臂尾部抬高规定度数,便于安装工人连接平衡臂拉杆,当两根拉杆连接无误后,汽车吊再将平衡臂放平,结束平衡臂安装流程。当平衡臂安装完工以后,要将第一车载摄像机BS-CA33-IP、以及激光测距传感器反射板换到起重臂方向同样位置固定好,等待接收起重臂安装的信号。According to the tower crane installation process, under the condition that the tower crane base meets the standard requirements, the tower crane foundation section must be installed first. The instructions are required to be fixed on the center axis of the horizontal braces on both sides of the foundation section. At the same time, the installation instructions of the laser ranging sensor reflector plate are required to be installed at 90 degrees to the center line of the horizontal braces of the foundation segment, and then aligned with the host CXM300 system of the base station. Connect, power on, and start working. Since the size of each process is different, the space algorithm will also be different, until the tower cap is installed in place, the installation alignment reference station will not move. However, after the tower body and tower cap are installed in place, the installation alignment reference station should be moved to the revolving tower, and the second and third satellite positioning antenna AT300 and the balance arm should be installed on the center axis of the revolving tower in a horizontal line. Then, install the first vehicle-mounted camera BS-CA33-IP in the installation direction of the tower cap by the balance arm, and align the camera head at the joint of the balance arm and the turntable to provide video support for the installation of the balance arm; the first vehicle-mounted camera BS-CA33 -After the IP is installed in place, install the reflector of the laser ranging sensor at 3M on the outer centerline of the balance arm direction sleeve, ready to receive the reflected laser ranging signal; The three-satellite positioning antenna AT300 is connected to the host CXM300 of the alignment base station, and the power of the host is turned on after correct. At this time, the host of the alignment base station CXM300 will automatically calculate the position coordinates of the host's second and third satellite positioning antennas AT300, and connect the two The coordinate information is sent to the car hoisting monitor and the on-site dispatch command platform through the first network bridge AP20, providing target position data for the car hoisting standard section, and providing target position data for the on-site dispatch command platform to command the car hoisting standard section. When the balance arm is installed in place, raise the tail of the balance arm by a specified degree according to the program requirements, so that the installer can connect the balance arm pull rod. After the installation of the balance arm is completed, the first on-board camera BS-CA33-IP and the reflector of the laser ranging sensor should be changed to the same position in the direction of the boom and fixed, waiting to receive the signal of the boom installation.
3:安装对位移动站:3: Install the alignment mobile station:
系统组成:它是由第四卫星定位天线、第五卫星定位天线,第三数传电台915L30,1台激光测距传感器HJ-70K, 第二车载摄像机BS-CA33-IP,对位移动站主机CXM300,第二交换机005,第二网桥AP20, 锂电池KMW-60A和一个移动设备箱等组成,原理图如图4所示。System composition: it consists of the fourth satellite positioning antenna, the fifth satellite positioning antenna, the third digital radio station 915L30, a laser ranging sensor HJ-70K, the second vehicle camera BS-CA33-IP, and the positioning mobile station host CXM300,
工作时,对位移动站主机CXM300会自动计算出主机第四卫星定位天线、第五卫星定位天线AT300的位置坐标及对地面的高度;第三数传电台915L30会不断与卫星定位固定基站通讯,通过卫星定位固定基站不断修正塔机对位移动站主机CXM300位置坐标及对地面的高度,同时对位移动站主机CXM300会不断将第四卫星定位天线、第五卫星定位天线坐标信息通过第二网桥AP20送给汽车吊吊装监护仪、以及现场调度指挥平台,为汽车吊吊装标准节或者平衡臂、起重臂提供当前标准节位置数据,为现场调度指挥平台指挥汽车吊吊装标准节或者平衡臂、起重臂提供当前标准节位置数据。激光测距传感器HJ-70K的精确度为1MM,它是负责为塔机相关设备安装到位提供设备当前高度的精确对位使用,它与对位移动站主机CXM300连接,由对位移动站主机CXM300计算出当前高度然后通过第二网桥AP20送给汽车吊吊装监护仪、以及现场调度指挥平台,为汽车吊吊装标准节或者平衡臂、起重臂提供当前标准节位置数据,为现场调度指挥平台指挥汽车吊吊装标准节或者平衡臂、起重臂提供当前标准节位置数据。第二车载摄像机BS-CA33-IP是固定在当前设备上,安装时负责当前设备对位时的视频监控。When working, the host CXM300 of the alignment mobile station will automatically calculate the position coordinates of the host's fourth satellite positioning antenna, the fifth satellite positioning antenna AT300 and the height to the ground; the third digital radio station 915L30 will continuously communicate with the satellite positioning fixed base station, Through the satellite positioning fixed base station, the position coordinates of the tower crane aligning mobile station host CXM300 and the height to the ground are continuously corrected. The bridge AP20 is sent to the car hoisting monitor and the on-site dispatching command platform, providing the current standard section position data for the car hoisting standard section or the balance arm, and the jib, and instructing the car hoisting standard section or the balance arm for the on-site dispatch command platform. , The boom provides the current standard section position data. The accuracy of the laser ranging sensor HJ-70K is 1MM. It is responsible for providing accurate alignment of the current height of the equipment for the installation of tower crane related equipment. Calculate the current height and then send it to the car hoisting monitor and the on-site dispatching command platform through the second network bridge AP20 to provide the current standard section position data for the car hoisting standard section or the balance arm and the jib, and provide the on-site dispatching command platform. Command the car hoist to hoist the standard section or the balance arm and the boom to provide the current standard section position data. The second vehicle-mounted camera BS-CA33-IP is fixed on the current equipment, and is responsible for video monitoring when the current equipment is aligned.
实现过程如下:The implementation process is as follows:
按照塔机安装流程塔身标准节到塔帽安装过程中,安装对位移动站的第四卫星定位天线、第五卫星定位天线AT300安装位置应该与安装对位基准站的天线AT300位置安装在相同位置,并且将激光测距传感器HJ-70K按照说明书要求,与卫星定位天线AT300成90度安装在标准节横撑中心轴线上,将第二车载摄像机BS-CA33-IP安装在标准节外侧,摄像头对准下标准节连接处,然后将对位移动站主机CXM300固定好,就可以开机通电工作了。当塔身、塔帽安装就位后,将安装对位移动站安装到平衡臂中心轴线上,第四卫星定位天线、第五卫星定位天线之间控制在3-5M距离,形成两点成一线形态,然后,将激光测距传感器HJ-70K安装在平衡臂与回转台方向中心线上,激光测距传感器HJ-70K头垂直向下,准备向安装在套架上的反射板发射激光测距信号;将第二车载摄像机BS-CA33-IP通过固定支架安装在平衡臂最前端离平衡臂连接耳3M以内地方,第二车载摄像机BS-CA33-IP对准平衡臂连接耳,然后固定好对位移动站主机CXM300,将第四卫星定位天线、第五卫星定位天线AT300、激光测距传感器HJ-70K与对位移动站主机CXM300连接,第二车载摄像机BS-CA33-IP与第二交换机连接。当平衡臂安装就位后就要将卫星对位移动站CXM300系统天线在吊装前就要安装到起重臂中心轴线上,保持3-5M距离,然后,将激光测距传感器HJ-70K安装在起重臂与回转台方向中心线上,激光测距传感器HJ-70K头垂直向下,准备向安装在套架上的反射板发射激光测距信号;然后固定好对位移动站主机CXM300,将第四卫星定位天线、第五卫星定位天线AT300与对位移动站主机CXM300连接,无误后开机。According to the tower crane installation process, during the installation process from the tower body standard section to the tower cap, the fourth satellite positioning antenna and fifth satellite positioning antenna AT300 of the mobile station should be installed in the same position as the AT300 antenna of the alignment base station. position, and install the laser ranging sensor HJ-70K on the central axis of the standard section horizontal support at 90 degrees to the satellite positioning antenna AT300 according to the requirements of the manual, and install the second vehicle camera BS-CA33-IP on the outside of the standard section. Aim at the connection of the lower standard section, and then fix the CXM300 of the mobile station host, and you can turn on the power and work. After the tower body and the tower cap are installed in place, install the mobile station on the center axis of the balance arm, and control the distance between the fourth satellite positioning antenna and the fifth satellite positioning antenna within 3-5M, forming two points in a line Then, install the laser ranging sensor HJ-70K on the center line of the balance arm and the direction of the turntable, the head of the laser ranging sensor HJ-70K is vertically downward, and prepare to emit laser ranging to the reflector installed on the set frame. Signal; install the second vehicle camera BS-CA33-IP at the front end of the balance arm within 3M from the balance arm connecting ear through the fixing bracket, and align the second vehicle camera BS-CA33-IP with the balance arm connecting ear, and then fix it properly. Position the mobile station host CXM300, connect the fourth satellite positioning antenna, fifth satellite positioning antenna AT300, laser ranging sensor HJ-70K with the positioning mobile station host CXM300, and connect the second vehicle camera BS-CA33-IP with the second switch . When the balance arm is installed in place, the satellite alignment mobile station CXM300 system antenna should be installed on the center axis of the boom before hoisting, keeping a distance of 3-5M, and then the laser ranging sensor HJ-70K should be installed on the On the center line of the direction of the boom and the turntable, the laser ranging sensor HJ-70K head is vertically downward, ready to transmit the laser ranging signal to the reflector installed on the frame; The fourth satellite positioning antenna and the fifth satellite positioning antenna AT300 are connected to the host CXM300 of the alignment mobile station, and power on after correct.
4:汽车吊吊装对位监护仪:4: Car hoisting alignment monitor:
系统组成:它是由车身水平传感器ZCT21M-LNQ、支腿液压传感器YYQ-35、力矩限制器、风速传感器YGC-FS、汽车吊吊装对位监护仪S7-200SMARTSR20、继电器控制板、第三交换机005、触摸屏TCP7062Ti、脸谱识别传感器KAIris200、IP对讲机FY-F30、数传模块915L30、4G通讯模块LTE-DTU-360及视频监控系统的半球摄像机S820IPC、吊钩监控摄像机CX-SXJ100、录像机DS-7804HQH、显示器LED1401、第三网桥1AP20、第四网桥2AP20及嵌入式安全保护软件、流程管理软件及卫星对位计算软件等组成。原理图如图5、图6所示。System composition: it is composed of body level sensor ZCT21M-LNQ, outrigger hydraulic sensor YYQ-35, torque limiter, wind speed sensor YGC-FS, car hoisting alignment monitor S7-200SMARTSR20, relay control board,
工作时,汽车吊司机通过脸谱识别传感器KAIris200刷脸然后由触摸屏TCP7062Ti、经过交换机005、4G通讯模块LTE-DTU-360将司机信息送到塔机无忧吊装网云平台,由调度指挥平台及相关管理人员上网确认,当监护仪主机S7-200SMARTSR20收到调度指挥平台及相关管理人员确认信息后,系统开始工作。触摸屏TCP7062Ti内嵌入有流程管理软件、安全防护软件及对位计算软件,内装有报警器,当有报警事项发生时会自动发出报警声音。车身水平传感器ZCT21M-LNQ主要负责车身水平度检测,它可以检测X/Y两个方向的水平度,然后将水平信号送给监护仪主机S7-200SMARTSR20,工作时当车身倾斜超过额定标准时,监护仪主机S7-200SMARTSR20会立即发出报警声音,同时输出控制信号,控制起重机继续起升作业或者回转作业,避免发生重大安全事故;同时监护仪主机S7-200SMARTSR20会通过第三交换机005、4G通讯模块LTE-DTU-360将信息发送到塔机无忧吊装网云平台,由调度指挥平台及相关管理人员上网监控,当调度指挥平台及相关管理人员会通过IP对讲机对汽车吊司机进行干预,汽车吊司机也可以通过IP对讲机与调度指挥平台及相关管理人员进行沟通。支腿液压传感器是负责检测四个支腿压力,当某一个支腿失压时,监护仪主机S7-200SMARTSR20会立即发出报警声音,同时输出控制信号,禁止起重机继续起升作业或者回转作业,避免发生重大安全事故;同时监护仪主机S7-200SMARTSR20会通过第三交换机005、4G通讯模块LTE-DTU-360将信息发送到塔机无忧吊装网云平台,由调度指挥平台及相关管理人员上网监控,当调度指挥平台及相关管理人员会通过IP对讲机对汽车吊司机进行干预,汽车吊司机也可以通过IP对讲机与调度指挥平台及相关管理人员进行沟通。When working, the driver of the truck crane swipes his face through the face recognition sensor KAIris200, and then sends the driver information to the tower crane worry-free hoisting network cloud platform through the touch screen TCP7062Ti, through the
力矩限制器是利用原厂设备,通过通讯或者另外采集力矩信号获得,当汽车吊工作力矩超过额定力矩时,监护仪主机S7-200SMARTSR20会立即进行报警及控制,从而确保吊装安全;同时监护仪主机S7-200SMARTSR20会通过第三交换机005、4G通讯模块LTE-DTU-360将信息发送到塔机无忧吊装网云平台,由调度指挥平台及相关管理人员上网监控,当调度指挥平台及相关管理人员会通过IP对讲机对汽车吊司机进行干预,汽车吊司机也可以通过IP对讲机与调度指挥平台及相关管理人员进行沟通;The torque limiter is obtained by using the original equipment through communication or other acquisition of torque signals. When the working torque of the car crane exceeds the rated torque, the monitor host S7-200SMARTSR20 will immediately alarm and control to ensure the safety of lifting; at the same time, the monitor host S7-200SMARTSR20 will send the information to the tower crane worry-free hoisting cloud platform through the
风速传感器YGC-FS将采集的风速信号不断送给监护仪主机S7-200SMARTSR20,监护仪主机S7-200SMARTSR20,经过比较后将显示信号送给触摸屏,控制信号送给继电器板,通讯信号送给通过第三交换机005、4G通讯模块LTE-DTU-360将信息发送到塔机无忧吊装网云平台,由调度指挥平台及相关管理人员上网监控,当调度指挥平台及相关管理人员会通过IP对讲机对汽车吊司机进行干预,汽车吊司机也可以通过IP对讲机与调度指挥平台及相关管理人员进行沟通。The wind speed sensor YGC-FS continuously sends the collected wind speed signal to the monitor host S7-200SMARTSR20 and the monitor host S7-200SMARTSR20. After comparison, the display signal is sent to the touch screen, the control signal is sent to the relay board, and the communication signal is sent to the Three switches 005, 4G communication module LTE-DTU-360 send the information to the tower crane worry-free hoisting network cloud platform, which is monitored by the dispatching command platform and related management personnel online. The crane driver intervenes, and the truck crane driver can also communicate with the dispatch command platform and related management personnel through the IP walkie-talkie.
司机室半球摄像机S820IPC及吊钩监控摄像机CX-SXJ100、将视频监控信号送给录像机DS-7804HQH、录像机再送给显示器LED1401进行显示,供司机工作时监控使用,同时通过第三网桥1AP20将视频信息送给调度指挥平台及相关管理人员监控,便于决策指挥。通过第四网桥2AP20接收来自塔机安装对位基准站的视频信号及塔机安装对位移动站的视频信号;这样司机不但可以看到吊钩视频,同时还可以看到塔机对位固定及移动信号,The driver's cab dome camera S820IPC and the hook monitoring camera CX-SXJ100, send the video monitoring signal to the video recorder DS-7804HQH, and the video recorder to the display LED1401 for display, for the driver to monitor the use of the work, at the same time through the third bridge 1AP20 video information Send it to the dispatching command platform and related management personnel for monitoring, which is convenient for decision-making and commanding. Through the fourth network bridge 2AP20, the video signal from the tower crane installation alignment reference station and the video signal from the tower crane installation alignment mobile station are received; in this way, the driver can not only see the video of the hook, but also the alignment and fixation of the tower crane. and mobile signals,
数传电台915L30作为备用通道,当4G通讯LTE-DTU-360有问题时,系统自动切换到数传状态下与调度指挥平台通讯,确保在任何条件下通讯畅通。The data transmission station 915L30 is used as a backup channel. When there is a problem with the 4G communication LTE-DTU-360, the system automatically switches to the data transmission state to communicate with the dispatching command platform to ensure smooth communication under any conditions.
实现过程:Implementation process:
第一步,要选择工作模式,是准备安装还是拆除,模式选择完了后按【确认键】确认,The first step is to select the working mode, whether to prepare for installation or removal.
第二步,选择安装部位:塔身安装与否、平衡臂安装与否、起重臂安装与否、等,选定以后按【确认键】确认;The second step, select the installation location: whether the tower body is installed or not, whether the balance arm is installed or not, whether the lifting arm is installed or not, etc. After selecting, press [OK] to confirm;
第三步,选择安装工序,比如:现在安装塔身部位的第几节标准节,选定以后按【确认键】确认;The third step, select the installation process, such as: now install the standard section of the tower body part, after selecting, press [OK] to confirm;
选择完以后开始工作;如果选择的工序或者模式与当前操作有错误,一旦进入工作状态,系统马上会报警控制,系统不能正常作业;从而保证有序、安全、高效安装或者拆除;Start work after selection; if the selected process or mode is wrong with the current operation, once it enters the working state, the system will immediately alarm and control, and the system cannot operate normally; thus ensuring orderly, safe and efficient installation or removal;
如果选择的是塔身安装,当前执行的是系统开始执行塔身安装程序,此时,触摸屏上会显示塔机第一节标准节目标坐标位置;标准节离地面标准高度,当吊钩吊起已经安装好移动对位站的标准节时,触摸屏会显示当前标准节位置坐标及离地面高度,当前标准节向目标位置移动时吊钩吊挂的标准节底部离地面高度必须大于基础节高度,否则,汽车吊吊装监护仪会禁止回转,防止标准节与基础节产生碰撞;只有当当前吊装的标准节底部高于3M时,吊装监护仪下才允许汽车吊做回转操作;If the tower body installation is selected, the system is currently executing the tower body installation program. At this time, the touch screen will display the target coordinate position of the first standard section of the tower crane; the standard section is at a standard height from the ground, and when the hook is lifted When the standard section of the mobile alignment station has been installed, the touch screen will display the coordinates of the current standard section and the height from the ground. When the current standard section moves to the target position, the height from the bottom of the standard section hung by the hook must be greater than the height of the base section. Otherwise, the car hoisting monitor will be forbidden to rotate to prevent the collision between the standard section and the base section; only when the bottom of the standard section currently hoisted is higher than 3M, the car hoist is allowed to do the turning operation under the hoisting monitor;
然后,触摸屏上会显示当前标准节位置坐标与基础节位置坐标之间最近距离及高度,司机依据目标坐标及当前坐标逐渐调整回转角度及幅度,当目标坐标与当前坐标重合时,就可以操作吊钩下降手柄,慢慢将标准节放到基础节上,由安装工人去拧紧每个螺栓,当最后一颗螺栓扭紧后,监理人员拍照上传,经过现场调度指挥平台【确认】后,由安装工人将卫星天线,激光测距传感器、摄像机分别拆除,放在移动设备箱内,随起重钢丝绳一起吊运到下一个准备吊装的目标标准节位置,再进入下一道安装流程;Then, the touch screen will display the closest distance and height between the position coordinates of the current standard section and the position coordinates of the base section. The driver gradually adjusts the rotation angle and amplitude according to the target coordinates and the current coordinates. When the target coordinates coincide with the current coordinates, the crane can be operated. Hook down the handle, slowly put the standard section on the base section, and the installation worker will tighten each bolt. When the last bolt is tightened, the supervisor will take a picture and upload it. After the on-site dispatch command platform [confirm], the installation will The worker removes the satellite antenna, the laser ranging sensor and the camera separately, puts them in the mobile equipment box, and hoists them together with the lifting wire rope to the next target standard section position to be hoisted, and then enters the next installation process;
塔身、塔帽安装程序类似;The tower body and tower cap installation procedures are similar;
当进入到平衡臂及起重臂安装环节时,首先要将工序选择到【平衡臂安装】或者【起重臂安装】,当选择了【平衡臂安装】此时汽车吊吊装监护仪会围绕塔身回转中心自动建立一个安全防护圈,在塔帽以下区域,自动禁止汽车吊将平衡臂吊运到安全防护圈内,以防不慎将平衡臂碰撞到塔身;对位方法是根据“两点确定一条直线”原理将平衡臂或者起重臂的两个卫星天线构成的一条直线,与回转塔上两个卫星天线构成的一条直线重合,然后再看平衡臂或者起重臂连接耳与回转台连接耳之间距离,如果连接耳对位准确,就可以操作吊钩下降手柄,慢慢将臂架连接耳放到回转台固定耳上,然后由安装工人将连接销轴穿进连接耳,插进鼻销,开好口;然后,根据指挥台命令,再吊起平衡臂尾部或者起重臂头部,配合安装工人安装拉杆;直到两边拉杆安装好了,根据命令将平衡臂或者起重臂放平;本次塔机安装任务完成。When entering the installation link of the balance arm and the boom arm, first select the process to [Balance Arm Installation] or [Boom Arm Installation]. When [Balance Arm Installation] is selected, the car hoisting monitor will surround the tower. The center of body rotation automatically establishes a safety protection circle. In the area below the tower cap, the truck crane is automatically prohibited from lifting the balance arm into the safety protection circle to prevent the balance arm from accidentally colliding with the tower body; the alignment method is based on the "two According to the principle of "point to determine a straight line", a straight line formed by the two satellite antennas of the balancing arm or boom coincides with a straight line formed by the two satellite antennas on the turret, and then look at the connecting ears of the balancing arm or the boom and the slewing The distance between the connecting ears of the table, if the connecting ears are accurately aligned, you can operate the hook lowering handle, slowly put the connecting ears of the boom on the fixing ears of the turntable, and then the installation worker will pass the connecting pins into the connecting ears, Insert the nose pin and open the mouth; then, according to the command of the command station, hoist the tail of the balance arm or the head of the boom, and cooperate with the installer to install the tie rod; until the tie rods on both sides are installed, according to the command, lift the balance arm or lift The arm is leveled; the tower crane installation task is completed.
司机在吊装时不仅通过触摸屏TCP7062Ti可以看到卫星对位坐标等信息,还可以通过显示器LED1401,吊钩摄像机CX-SXJ100及标准节或者平衡臂、起重臂上的摄像机BS-CA33-IP可以清楚监控到现场全过程安装视频,使司机有亲临现场的体验。When hoisting, the driver can not only see the satellite alignment coordinates and other information through the touch screen TCP7062Ti, but also through the display LED1401, the hook camera CX-SXJ100 and the standard section or the camera BS-CA33-IP on the balance arm and the jib can be clearly seen The whole process of installation video is monitored to the scene, so that the driver can experience the scene in person.
5:现场指挥调度平台及视频监控系统:5: On-site command and dispatch platform and video surveillance system:
由一台扫描仪Perfection V19、激光打印机P1108、GPS/4G通讯MD620、对讲指挥机M800、交换机005、笔记本电脑DELLG7等组成。视频部分由录像机DS-7816HQH +硬盘+显示器DELL1912H+交换机005+视频接收网桥AP20等组成。调度指挥人员可以通过显示器DELL1912H监控到现场所有视频操作工况,通过对讲指挥机M800与安装作业人员、监理人员、作业司机等进行对话,从而有效协调各工种环节及步骤。现场指挥调度平台工作原理图如图7所示。It consists of a scanner Perfection V19, laser printer P1108, GPS/4G communication MD620, intercom commander M800,
所述现场指挥调度平台的调度指挥软件安装在笔记本电脑DELLG7内;所述扫描仪Perfection V19、激光打印机P1108、全站仪(客户设备)与笔记本电脑DELLG7连接;所述笔记本电脑DELLG7通过网线与塔机无忧吊装网云平台连接;所述笔记本电脑DELLG7通过交换机005及GPS/4G通讯MD620与塔机无忧吊装网云平台连接;所述对讲指挥机M800的服务软件安装在塔机无忧吊装网云平台云服务器上,对讲指挥机M800通过交换机005和笔记本电脑DELLG7、网线与塔机无忧吊装网云平台连接,塔机无忧吊装网云平台通过无线与汽车吊吊装监护仪、塔机加节降节监护仪、塔机螺栓监护仪等设备的IP对讲机AP20连接;所述视频部分录像机DS-7816HQH 与显示器DELL1912H连接,录像机DS-7816HQH又通过交换机005与视频接收网桥AP20连接;手机APP与塔机无忧吊装网云平台连接,调度指挥人员可以在任何位置通过手机APP查看现场图片、视频、文字等全方位信息,可以实时协调现场施工操作,确保安全、高效作业。The dispatch command software of the on-site command and dispatch platform is installed in the notebook computer DELLG7; the scanner Perfection V19, the laser printer P1108, and the total station (customer equipment) are connected with the notebook computer DELLG7; the notebook computer DELLG7 is connected to the tower through a network cable. The machine is connected to the network cloud platform of worry-free hoisting; the laptop DELLG7 is connected to the tower crane network cloud platform through
信息处理部分主要由笔记本电脑DELLG7、激光打印机P1108、交换机005、GPS/4G通讯模块MD620、数传电台915L30及塔机无忧吊装网组成;笔记本电脑daLLG7负责接收现场人员、设备及各方面信息,然后由智能管理软件对其进行分析、判断、处理,由于笔记本电脑与塔机无忧吊装网平台链接,可以及时获取塔机无忧吊装网平台全方位信息支持,确保、塔机安装、运行、拆除安全高效,激光打印机P1108是负责文件输出打印。手机APP,调度指挥人员可以在任何位置通过手机APP查看现场图片、视频、文字等全方位信息,可以实时协调现场施工操作,确保安全、高效作业。The information processing part is mainly composed of notebook computer DELLG7, laser printer P1108,
工作时,调度指挥平台通过网络与塔机无忧吊装网平台连接,吊装作业时在塔机无忧吊装网平台上会看到汽车吊监控到监护仪终端送来的各种监控及报警数据,如果发现某一道工序不规范、不标准,或者某一安全参数出现报警,调度指挥人员可以通过对讲机对其及时予以纠正;同时,调度指挥人员可以通过显示器,查看现场视频,对现场施工过程进行全程监控,当发现有违章作业等不安全动作时,可以通过对讲机及时予以纠正,避免发生安全事故。When working, the dispatching command platform is connected to the tower crane worry-free hoisting network platform through the network. During the hoisting operation, you will see various monitoring and alarm data sent by the truck crane to the monitor terminal on the tower crane worry-free hoisting network platform. If it is found that a certain process is not standardized or non-standard, or a certain safety parameter is alarmed, the dispatching commander can correct it in time through the walkie-talkie; at the same time, the dispatching commander can view the on-site video through the monitor, and conduct the entire construction process on-site. Monitoring, when unsafe actions such as illegal operations are found, they can be corrected in time through the walkie-talkie to avoid safety accidents.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201922186106.6U CN211444763U (en) | 2019-12-09 | 2019-12-09 | A tower crane installation intelligent alignment navigation system |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201922186106.6U CN211444763U (en) | 2019-12-09 | 2019-12-09 | A tower crane installation intelligent alignment navigation system |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN211444763U true CN211444763U (en) | 2020-09-08 |
Family
ID=72318192
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201922186106.6U Expired - Fee Related CN211444763U (en) | 2019-12-09 | 2019-12-09 | A tower crane installation intelligent alignment navigation system |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN211444763U (en) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110980526A (en) * | 2019-12-09 | 2020-04-10 | 宜昌市创星电子技术发展有限公司 | Intelligent alignment navigation system for tower crane installation |
| CN113291980A (en) * | 2021-05-14 | 2021-08-24 | 上海振华重工(集团)股份有限公司 | Multisource fault alarm system suitable for automatic crane |
| CN118463983A (en) * | 2024-07-15 | 2024-08-09 | 北京大成国测科技股份有限公司 | Total station measuring method and system based on 4G DTU |
-
2019
- 2019-12-09 CN CN201922186106.6U patent/CN211444763U/en not_active Expired - Fee Related
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110980526A (en) * | 2019-12-09 | 2020-04-10 | 宜昌市创星电子技术发展有限公司 | Intelligent alignment navigation system for tower crane installation |
| CN113291980A (en) * | 2021-05-14 | 2021-08-24 | 上海振华重工(集团)股份有限公司 | Multisource fault alarm system suitable for automatic crane |
| CN118463983A (en) * | 2024-07-15 | 2024-08-09 | 北京大成国测科技股份有限公司 | Total station measuring method and system based on 4G DTU |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN112758824B (en) | An unmanned control system for tower crane | |
| CN112794208B (en) | Hoisting method, hoisting control system and engineering machinery | |
| CN207293970U (en) | The tower crane operation monitoring system of wisdom building site control platform | |
| CN112479038A (en) | Tower crane operation visual monitoring system | |
| CN115448185B (en) | Super large intelligent tower crane and construction method | |
| CN213126247U (en) | Intelligent monitoring system for potential safety hazards in construction of metro vehicle sections | |
| CN103926903A (en) | Safety monitoring system for bridge girder erection machine | |
| CN114229724A (en) | Remote control system and method for tower crane | |
| WO2018211489A1 (en) | A crane ground control operating system | |
| CN207457755U (en) | A kind of extra-high voltage iron tower group founds overall process monitoring early warning and safety device | |
| CN118536941A (en) | A smart construction site management system | |
| CN110980526A (en) | Intelligent alignment navigation system for tower crane installation | |
| CN205634668U (en) | Virtual command system of large -scale hoist and mount operation | |
| CN214298952U (en) | Unmanned control system of tower crane | |
| CN116152712A (en) | A Visualization Method of Tower Crane Hook Based on Edge-Cloud Collaborative Computing | |
| CN210885030U (en) | Tower crane unmanned control system and tower crane system | |
| CN203204439U (en) | Wireless monitoring device for safety of tower erection | |
| CN205222539U (en) | Solar towers hangs collision avoidance system | |
| CN118992867A (en) | Automatic obstacle avoidance system and method for tower crane | |
| CN207483203U (en) | Blind auxiliary hoisting device is mended in a kind of visualization | |
| CN206927511U (en) | A kind of tower crane safety monitoring system | |
| KR20230148313A (en) | System for warning and displaying wind velocity and weight in tower crane | |
| CN211338571U (en) | Black box | |
| CN117342448A (en) | A method to prevent collision between tower crane and adjacent fixed buildings | |
| CN217478903U (en) | Deformation monitoring device for tower crane |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20200908 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |