CN211172952U - Automatic painting device - Google Patents
Automatic painting device Download PDFInfo
- Publication number
- CN211172952U CN211172952U CN201921795838.9U CN201921795838U CN211172952U CN 211172952 U CN211172952 U CN 211172952U CN 201921795838 U CN201921795838 U CN 201921795838U CN 211172952 U CN211172952 U CN 211172952U
- Authority
- CN
- China
- Prior art keywords
- telescopic link
- wall
- automatic painting
- painting device
- guide rail
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Landscapes
- Spray Control Apparatus (AREA)
Abstract
本实用新型公开了一种自动粉刷装置,包括移动小车,所述移动小车的靠墙侧和靠墙侧的两端相邻侧均安装有障碍物感应器,移动小车上安装有伸缩连杆机构和控制伸缩连杆机构上下伸缩的控制装置,伸缩连杆机构的上端安装有喷刷机构,喷刷机构上装有墙顶距离感应器,还包括控制所述的控制装置、喷刷机构、障碍物感应器和墙顶距离感应器的单片机系统以及给控制装置、喷刷机构、障碍物感应器、墙顶距离感应器和单片机系统供电的供电装置。本实用新型的自动粉刷装置将人力操作的粉刷转变为自动粉刷,减低了人工成本,提高了工作效率,保证了墙面的平整度,避免了对人体的伤害。
The utility model discloses an automatic painting device, which comprises a mobile trolley. Obstacle sensors are installed on the wall side and the two adjacent sides of the wall side of the mobile trolley, and a telescopic link mechanism is installed on the mobile trolley. and a control device for controlling the up and down extension of the telescopic link mechanism, the upper end of the telescopic link mechanism is equipped with a spray brush mechanism, the spray brush mechanism is equipped with a distance sensor from the top of the wall, and also includes the control device, spray brush mechanism, obstacles The single-chip microcomputer system of the sensor and the wall-top distance sensor, and the power supply device for supplying power to the control device, the spraying mechanism, the obstacle sensor, the wall-top distance sensor and the single-chip computer system. The automatic painting device of the utility model converts manual painting into automatic painting, reduces labor cost, improves work efficiency, ensures the flatness of the wall surface, and avoids harm to human body.
Description
技术领域technical field
本实用新型涉及自动粉刷技术领域,尤其涉及一种自动粉刷装置。The utility model relates to the technical field of automatic painting, in particular to an automatic painting device.
背景技术Background technique
随着社会科技不断发展,自动化生产方式已经普及到人们生活的方方面面,许多原本需要人力操作的工作逐渐被自动化机械所取代。一方面,粉刷工作对人体伤害较大,轻则导致呼吸道或者皮肤类疾病,重则导致癌症,人工粉刷效率较低。另一方面,而目前的机器操作为办自动化操作,难以灵活判断墙面状况,无法保证粉刷墙面的平整度。因而,粉刷工作目前仍以人力操作为主,且人工的成本较高。With the continuous development of social science and technology, automated production methods have been popularized in all aspects of people's lives, and many jobs that originally required manual operations have been gradually replaced by automated machinery. On the one hand, the painting work causes great harm to the human body, ranging from respiratory or skin diseases, to cancer in severe cases, and the efficiency of manual painting is low. On the other hand, the current machine operation is automated, so it is difficult to flexibly judge the condition of the wall surface, and the flatness of the painted wall surface cannot be guaranteed. Therefore, the painting work is still mainly operated by manpower, and the labor cost is relatively high.
实用新型内容Utility model content
为了解决上述问题之一,本实用新型提供一种自动粉刷装置,将人力操作的粉刷转变为自动粉刷,减低了人工成本,提高了工作效率,避免了对人体的伤害。In order to solve one of the above problems, the present invention provides an automatic painting device, which converts manual painting into automatic painting, reduces labor costs, improves work efficiency, and avoids harm to human body.
为实现上述目的,本实用新型提供一种自动粉刷装置,包括移动小车,所述移动小车的靠墙侧和靠墙侧的两端相邻侧均安装有障碍物感应器,移动小车上安装有伸缩连杆机构和控制伸缩连杆机构上下伸缩的控制装置,伸缩连杆机构的上端安装有喷刷机构,喷刷机构上装有墙顶距离感应器,还包括控制所述的控制装置、喷刷机构、障碍物感应器和墙顶距离感应器的单片机系统以及给控制装置、喷刷机构、障碍物感应器、墙顶距离感应器和单片机系统供电的供电装置。In order to achieve the above purpose, the present utility model provides an automatic painting device, which includes a mobile trolley. Obstacle sensors are installed on the side of the mobile trolley and the adjacent sides of the two ends of the side against the wall. The mobile trolley is installed with an obstacle sensor. The telescopic link mechanism and the control device for controlling the up and down expansion of the telescopic link mechanism, the upper end of the telescopic link mechanism is provided with a spray brush mechanism, the spray brush mechanism is provided with a distance sensor from the top of the wall, and also includes a control device for controlling the said control device, spray brush mechanism The single-chip microcomputer system for the mechanism, the obstacle sensor and the wall-top distance sensor, and the power supply device for powering the control device, the spraying mechanism, the obstacle sensor, the wall-top distance sensor and the single-chip computer system.
作为本实用新型的进一步改进,所述伸缩连杆机构有两个,两个伸缩连杆机构沿靠墙侧和靠墙侧对侧间的中心连线方向并排布置,两个伸缩连杆机构之间通过若干横杆连接,两个伸缩连杆机构均由控制装置控制升降,喷刷机构安装在两个伸缩连杆机构的上端。As a further improvement of the present utility model, there are two telescopic link mechanisms. The two telescopic link mechanisms are arranged side by side along the direction of the center line between the side against the wall and the opposite side of the side against the wall. The two telescopic link mechanisms are connected up and down by a number of transverse rods, and the two telescopic link mechanisms are controlled up and down by the control device, and the spray brush mechanism is installed on the upper ends of the two telescopic link mechanisms.
作为本实用新型的更进一步改进,所述控制装置包括导轨滑块机构、丝杆螺母机构和驱动电机一,导轨滑块机构的导轨竖向布置在两个伸缩连杆机构旁且安装在移动小车上,丝杆螺母机构的螺母固定在导轨滑块机构的滑块上并且导轨滑块机构的滑块与接近伸缩连杆机构下端的横杆固定连接,驱动电机一与单片机系统连接。As a further improvement of the present invention, the control device includes a guide rail slider mechanism, a screw nut mechanism and a
作为本实用新型的更进一步改进,所述的各伸缩连杆机构包括多组剪刀式的连杆,多组剪刀式的连杆呈上下堆叠布置并且上下相邻的两组剪刀式的连杆彼此铰接连接,导轨滑块机构的滑块所安装的横杆的两端分别连接至两个伸缩连杆机构中的位于最下方的剪刀式的连杆的上端。As a further improvement of the present invention, each telescopic link mechanism includes multiple sets of scissor-type connecting rods. In hinged connection, the two ends of the transverse rod on which the slider of the guide rail slider mechanism is installed are respectively connected to the upper end of the lowermost scissor-type link in the two telescopic link mechanisms.
作为本实用新型的更进一步改进,所述喷刷机构包括抽料泵、机架、滚筒和喷头,滚筒和喷头安装在机架上并且滚筒位于喷头的两侧,抽料泵放置于移动小车上。As a further improvement of the present invention, the spraying mechanism includes a suction pump, a frame, a roller and a spray head, the roller and the spray head are installed on the frame, the rollers are located on both sides of the spray head, and the suction pump is placed on the mobile trolley .
作为本实用新型的更进一步改进,所述喷头的数量为若干,若干个喷头上下等间隔布置在机架上。As a further improvement of the present invention, the number of the nozzles is several, and the several nozzles are arranged on the frame at equal intervals up and down.
作为本实用新型的更进一步改进,所述滚筒为毛毡滚筒,毛毡滚筒竖向布置。As a further improvement of the present invention, the roller is a felt roller, and the felt roller is arranged vertically.
作为本实用新型的更进一步改进,所述移动小车包括车体和安装于车体底部的若干个车轮,其中的两个车轮安装有驱动电机二,驱动电机二与单片机系统连接,导轨滑块机构的导轨、障碍物感应器、驱动电机一、驱动电机二、抽料泵、供电装置和伸缩连杆机构均安装于车体上。As a further improvement of the present utility model, the mobile trolley includes a car body and a number of wheels installed at the bottom of the car body, two of which are installed with a second drive motor, the second drive motor is connected with the single-chip system, and the guide rail slider mechanism The guide rail, obstacle sensor,
作为本实用新型的更进一步改进,所述车体的底部还安装有行程开关,行程开关与单片机系统连接。As a further improvement of the present invention, a travel switch is also installed at the bottom of the vehicle body, and the travel switch is connected with the single-chip microcomputer system.
作为本实用新型的进一步改进,所述墙顶距离感应器、障碍物感应器均为超声波传感器。As a further improvement of the present invention, the wall top distance sensor and the obstacle sensor are both ultrasonic sensors.
与现有技术相比,本实用新型的自动粉刷装置的有益效果如下:Compared with the prior art, the beneficial effects of the automatic painting device of the present utility model are as follows:
(1)通过单片机系统的控制,使自动粉刷装置成为全自动化的机器,实现了自动化粉刷墙面,代替了人力操作的方式和半自动化机器操作的方式,极大减少了人工成本,提高了工作效率,保证了墙面的平整度,避免了对人体的伤害。(1) Through the control of the single chip system, the automatic painting device becomes a fully automatic machine, which realizes the automatic painting of the wall, replacing the manual operation method and the semi-automatic machine operation method, which greatly reduces the labor cost and improves the work. Efficiency ensures the flatness of the wall and avoids damage to the human body.
(2)通过设计带有滚筒与喷头的喷刷机构,使喷涂的动作与抹平墙面的动作同时进行,提高了粉刷效率以及墙面的平整度。(2) By designing a spraying mechanism with a roller and a spray head, the spraying action and the action of smoothing the wall are carried out at the same time, which improves the painting efficiency and the flatness of the wall.
(3)巧妙利用行程剪式伸缩架结构的杠杆和传动原理,设计出两个伸缩连杆机构,实现小范围移动控制大范围行程。(3) Using the lever and transmission principle of the stroke scissor telescopic frame structure, two telescopic link mechanisms are designed to realize a small range of movement and a large range of stroke control.
(4)利用超声波传感器测距,便于自动粉刷装置控制,提高了控制精度和自动粉刷装置定点的准确性,使自动粉刷装置能灵敏感应障碍物。(4) The ultrasonic sensor is used to measure the distance, which is convenient for the control of the automatic painting device, improves the control accuracy and the accuracy of the positioning of the automatic painting device, and enables the automatic painting device to sensitively sense obstacles.
(5)设计上更为精简。(5) The design is more streamlined.
通过以下的描述并结合附图,本实用新型将变得更加清晰,这些附图用于解释本实用新型的实施例。The present invention will become clearer from the following description in conjunction with the accompanying drawings, which are used to explain embodiments of the present invention.
附图说明Description of drawings
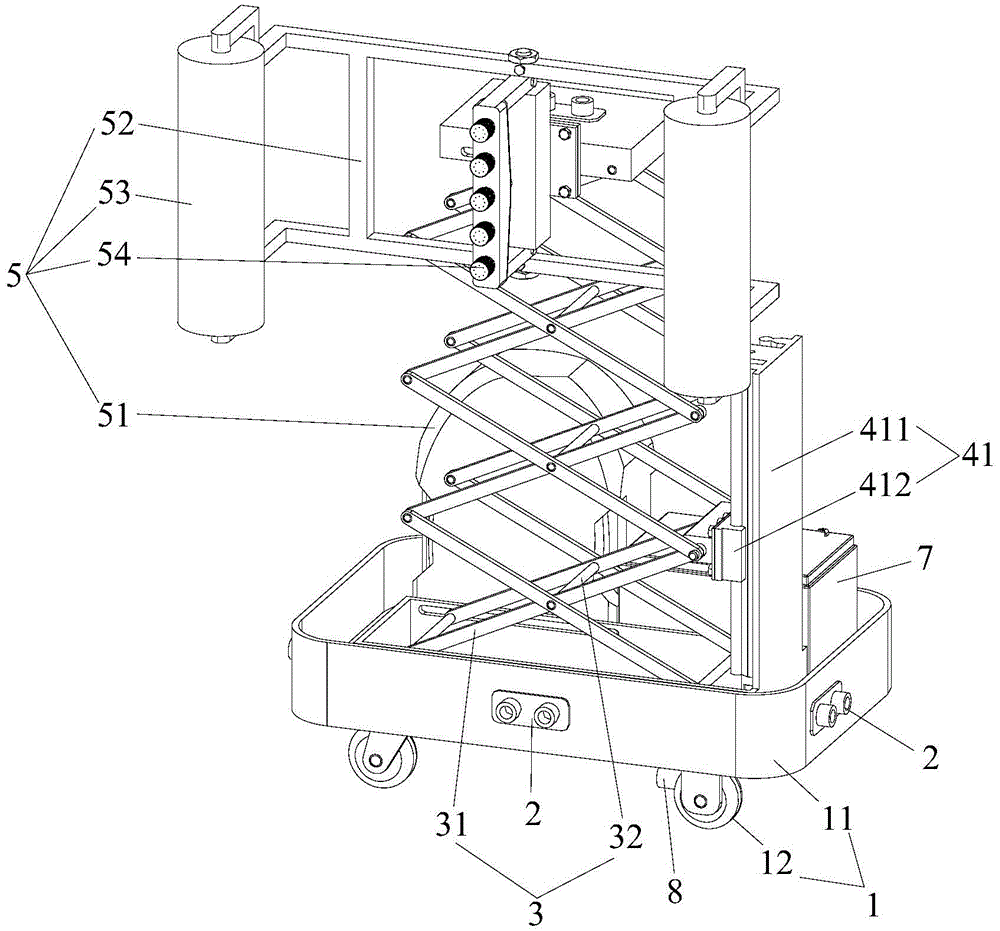
图1为本实用新型自动粉刷装置的立体示意图一。FIG. 1 is a perspective view one of the automatic painting device of the present invention.
图2为本实用新型自动粉刷装置的立体示意图二。FIG. 2 is a second perspective view of the automatic painting device of the present invention.
图3为本实用新型自动粉刷装置的立体示意图三。3 is a three-dimensional schematic diagram of the automatic painting device of the present invention.
图4为本实用新型自动粉刷装置的立体示意图四。FIG. 4 is a four-dimensional schematic diagram of the automatic painting device of the present invention.
图5为51单片机控制系统电路图。Fig. 5 is the circuit diagram of 51 single-chip microcomputer control system.
图6为电机驱动模块的电路图。FIG. 6 is a circuit diagram of a motor drive module.
图7为超声波感应模块的电路图。FIG. 7 is a circuit diagram of an ultrasonic sensing module.
图8为喷刷机构上的开关模块的电路图。FIG. 8 is a circuit diagram of a switch module on the spraying mechanism.
图9为总电路图。Figure 9 is a general circuit diagram.
具体实施方式的附图标号说明:移动小车1,车体11,车轮12,障碍物感应器2,伸缩连杆机构3,连杆31,横杆32,控制装置4,导轨滑块机构41,导轨411,滑块412,丝杆螺母机构42,螺母421,丝杆422,驱动电机一43,喷刷机构5,抽料泵51,机架52,滚筒53,喷头54,连接管55,墙顶距离感应器6,供电装置7,驱动电机二8。Description of the reference numerals of the specific embodiment:
具体实施方式Detailed ways
现在参考附图描述本实用新型的实施例,附图中类似的元件标号代表类似的元件。Embodiments of the present invention will now be described with reference to the accompanying drawings, in which like reference numerals represent like elements.
请参考图1-9,所述的自动粉刷装置包括移动小车1,所述移动小车1的靠墙侧和靠墙侧的两端相邻侧均安装有障碍物感应器2,移动小车1上安装有伸缩连杆机构3和控制伸缩连杆机构3上下伸缩的控制装置4,伸缩连杆机构3的上端安装有喷刷机构5,喷刷机构5上装有墙顶距离感应器6,还包括控制所述的控制装置4、喷刷机构5、障碍物感应器2和墙顶距离感应器6的单片机系统7以及给控制装置4、喷刷机构5、障碍物感应器2、墙顶距离感应器6和单片机系统供电的供电装置7。Please refer to FIGS. 1-9 , the automatic painting device includes a
所述伸缩连杆机构3有两个,两个伸缩连杆机构3沿靠墙侧和靠墙侧对侧间的中心连线方向并排布置,两个伸缩连杆机构3均由控制装置4控制升降。所述的各伸缩连杆机构3包括多组剪刀式的连杆31,多组剪刀式的连杆31呈上下堆叠布置并且上下相邻的两组剪刀式的连杆31彼此铰接连接。两个伸缩连杆机构3之间通过若干横杆32连接。There are two
所述控制装置4包括导轨滑块机构41、丝杆螺母机构42和驱动电机一43。导轨滑块机构41的导轨411竖向布置在两个伸缩连杆机构3旁且安装在移动小车1上,丝杆螺母机构42的螺母421固定在导轨滑块机构41的滑块412上并且导轨滑块机构41的滑块412与接近伸缩连杆机构3下端的横杆32固定连接。导轨滑块机构41的滑块412所安装的横杆32的两端分别连接至两个伸缩连杆机构3中的位于最下方的剪刀式的连杆31的上端。驱动电机一43与单片机系统连接。驱动电机一43位于移动小车1上并且连接丝杆螺母机构42的丝杆422的下端,用于控制两个伸缩连杆机构3的升降。丝杆螺母机构42的丝杆422竖向布置且安装在导轨411上。The
所述驱动电机一43为直流电机,通电时,丝杆422所连接的驱动电机一43受单片机系统控制转动,驱动电机一43驱动丝杆422转动,从而带动横杆32升降,而丝杆422与两个伸缩连杆机构3通过一根横杆32连接,进而带动两个伸缩连杆机构3上升、下降的动作。单片机系统控制驱动电机一43的转动角度,进而通过驱动电机一43控制丝杆422的转动圈数,从而控制伸缩连杆机构3的上升高度,从而实现不同高度的墙壁粉刷。丝杆422的总长限制伸缩连杆机构3的上升最大高度。The drive motor one 43 is a DC motor. When the power is turned on, the drive motor one 43 connected to the
所述喷刷机构5包括抽料泵51、机架52、滚筒53和喷头54。喷刷机构5的机架52安装在两个伸缩连杆机构3的上端,喷刷机构5的上下升降由两个伸缩连杆机构3控制。滚筒53和喷头54安装在机架52上并且滚筒53位于喷头54的两侧。抽料泵51放置于移动小车1上。所述喷头54的数量为若干,若干个喷头54上下等间隔布置在机架52上。在具体实施例中,喷头54的数量为五个,五个喷头54共同连接至一连接管55,抽料泵51通过管道与连接管55连接,连接管上装有打开和关闭通道55的开关,开关通过驱动电机三控制打开与关闭,驱动电机三可安装在机架52上,而且驱动电机三与单片机系统连接。所述滚筒53为毛毡滚筒,毛毡滚筒竖向布置。喷刷机构5的喷头54通过伸缩连杆机构3的升降实现上下喷涂墙壁的动作。抽料泵51和驱动电机三之间,抽料泵51先工作,以稳定涂料的压力,等需要喷涂时驱动电机三打开开关。The
所述障碍物感应器2、墙顶距离感应器6均为超声波传感器。墙顶距离感应器6安装在机架52的顶部,用于感应喷刷机构5顶部到墙顶的距离。障碍物感应器2安装在移动小车1的靠墙侧是用于感应障碍物,并将信息反馈给所述51单片机系统,控制装置整体转弯,障碍物感应器2安装在移动小车1的靠墙侧的两端相邻侧是用于感应移动小车1与墙面的距离。The
所述移动小车1包括车体11和安装于车体11底部的若干个车轮12。在具体实施例中,车轮12的数量为四个,其中的两个车轮12分别连接有一驱动电机二8,用于实现自动粉刷装置的整体来回运动,喷刷机构5的滚筒53通过移动小车1的来回运动实现抹平墙面的动作,抹平墙面的动作与喷涂墙面动作可以同时进行。驱动电机二8与单片机系统连接。导轨滑块机构41的导轨411、障碍物感应器2、驱动电机一43、驱动电机二8、抽料泵51、供电装置7和伸缩连杆机构3均安装于车体11上。供电装置7为蓄电池。The
所述车体11的底部还安装有行程开关,行程开关与单片机系统连接。行程开关用于结束墙面粉刷工作以及控制移动小车1转弯,从而进入下一墙面。单片机系统为51单片机。A travel switch is also installed on the bottom of the
工作时,51单片机控制驱动电机一43运转,驱动电机一43驱动丝杆422转动,从而带动横杆32与两个伸缩连杆机构3上升,随着伸缩连杆机构3的上升,伸缩连杆机构3上升到指定的高度时,51单片机控制驱动电机一43停止运转,伸缩连杆机构3停止上升。再由51单片机控制抽料泵51为喷刷机构5的喷头54提供涂料,51单片机控制驱动电机三打开开关,使喷刷机构5的喷头54进行喷涂动作,让涂料从喷头喷向墙面,同时喷头与滚筒也一起水平运动。同时51单片机控制驱动电机二8转动,使得移动小车1直线沿墙水平运动,使得喷刷机构5挤压墙面,达到将涂料抹平的效果,喷头54完成喷射涂料动作、滚筒53完成压实涂料动作。喷涂与抹平是从上到下进行,上面喷涂抹平之后,抽料泵51停止送料,51单片机控制驱动电机三关闭开关,驱动电机一43驱动丝杆422转动,从而带动横杆32与两个伸缩连杆机构3下降至另一高度,51单片机再次控制抽料泵51送料,51单片机再次控制驱动电机三打开开关,使得喷刷机构5在下降后的位置粉刷墙面。重复以上步骤,使墙面每个高度位置喷涂一次,直到墙面底部完成喷涂时结束,即完成了粉刷过程。When working, the 51 single-chip microcomputer controls the operation of the driving motor one 43, and the driving motor one 43 drives the
当移动小车1上的障碍物感应器2感应到另一墙面时,51单片机控制抽料泵51停止为喷刷机构5提供涂料,喷刷机构5停止粉刷墙面。51单片机控制自动粉刷装置整体转弯,使自动粉刷装置移动到下一墙面。When the
当伸缩连杆机构3上升至喷刷机构5上安装的墙顶距离感应器6感应到墙顶的距离,并且当该距离缩短至最小距离时,所述驱动电机一43停止运转,丝杆422停止转动,伸缩连杆机构3停止上升。When the
当移动小车1移动时,喷刷机构将同时实现喷涂以及抹平墙面的动作,使用非常方便,工作效率高。When the
以上结合最佳实施例对本实用新型进行了描述,但本实用新型并不局限于以上揭示的实施例,而应当涵盖各种根据本实用新型的本质进行的修改、等效组合。The present utility model has been described above with reference to the best embodiments, but the present utility model is not limited to the above disclosed embodiments, but should cover various modifications and equivalent combinations based on the essence of the present utility model.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201921795838.9U CN211172952U (en) | 2019-10-24 | 2019-10-24 | Automatic painting device |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201921795838.9U CN211172952U (en) | 2019-10-24 | 2019-10-24 | Automatic painting device |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN211172952U true CN211172952U (en) | 2020-08-04 |
Family
ID=71828269
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201921795838.9U Active CN211172952U (en) | 2019-10-24 | 2019-10-24 | Automatic painting device |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN211172952U (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110700524A (en) * | 2019-10-24 | 2020-01-17 | 广东技术师范大学 | Automatic whitewash device |
| CN112031347A (en) * | 2020-09-11 | 2020-12-04 | 东莞市风雨科技有限公司 | Automatic painting robot and method for building wall surface |
-
2019
- 2019-10-24 CN CN201921795838.9U patent/CN211172952U/en active Active
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110700524A (en) * | 2019-10-24 | 2020-01-17 | 广东技术师范大学 | Automatic whitewash device |
| CN112031347A (en) * | 2020-09-11 | 2020-12-04 | 东莞市风雨科技有限公司 | Automatic painting robot and method for building wall surface |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110700524A (en) | Automatic whitewash device | |
| CN109396088B (en) | PC component die table cleaning device and working method thereof | |
| CN106958373B (en) | Intelligent omnidirectional transfer platform parking system and method for automatic parking garage | |
| CN201235912Y (en) | Amphibian garbage cleaning robot | |
| CN112338069B (en) | Double-station bidirectional die changing trolley | |
| CN110171398A (en) | A kind of automatic car washing device | |
| CN105926908A (en) | Novel automatic-feeding intelligent cement paint whitewashing machine | |
| CN106798528B (en) | Omnidirectional mobile cleaning robot for household stairs | |
| CN104631791A (en) | Shear type lifting wall plastering machine driven by slider-crank and capable of fixing step-length and adjusting working range | |
| CN112617473B (en) | Height-adjustable goods shelf for hardware power supply | |
| CN205658258U (en) | Automatic oil spout brush dish device of cake mold | |
| CN112096133B (en) | Cleaning vehicle capable of automatically cleaning wall of swimming pool and cleaning method thereof | |
| CN104631793A (en) | Intelligent lifting plastering machine driven by chain wheels and chain and capable of fixing step-length and adjusting rolling brush angle | |
| CN206336988U (en) | A kind of lowering or hoisting gear of logistics equipment | |
| CN110841941B (en) | Automatic reversing photovoltaic cell cleaning robot and use method | |
| CN204892214U (en) | Large workpiece spraying system | |
| CN210966061U (en) | A pillar insulator cleaning machine | |
| CN112854682A (en) | Intelligent painting device for building wall | |
| CN219881257U (en) | Cylinder cleaning spraying vehicle | |
| CN114847244B (en) | Movable double-mode cocoon picking robot | |
| CN220666812U (en) | Wall surface coating machine | |
| CN218108078U (en) | Spraying equipment for garden construction | |
| CN214345209U (en) | Remove raise dust point dust pelletizing system | |
| CN110843408B (en) | Automatic wall plotter | |
| CN211419502U (en) | Automatic platform of dispatching a car |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |