CN209977571U - Spiral driving mechanism for pipeline robot - Google Patents
Spiral driving mechanism for pipeline robot Download PDFInfo
- Publication number
- CN209977571U CN209977571U CN201822178125.XU CN201822178125U CN209977571U CN 209977571 U CN209977571 U CN 209977571U CN 201822178125 U CN201822178125 U CN 201822178125U CN 209977571 U CN209977571 U CN 209977571U
- Authority
- CN
- China
- Prior art keywords
- driving
- supporting wheel
- pipeline robot
- holding body
- motor
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
- 230000008878 coupling Effects 0.000 claims abstract description 14
- 238000010168 coupling process Methods 0.000 claims abstract description 14
- 238000005859 coupling reaction Methods 0.000 claims abstract description 14
- 238000005452 bending Methods 0.000 abstract description 2
- 238000000034 method Methods 0.000 description 11
- 238000007689 inspection Methods 0.000 description 4
- 238000004140 cleaning Methods 0.000 description 2
- 230000018109 developmental process Effects 0.000 description 2
- 238000010586 diagram Methods 0.000 description 2
- 238000012423 maintenance Methods 0.000 description 2
- 239000010865 sewage Substances 0.000 description 2
- 230000032683 aging Effects 0.000 description 1
- 238000010276 construction Methods 0.000 description 1
- 238000009776 industrial production Methods 0.000 description 1
- 230000002572 peristaltic effect Effects 0.000 description 1
- 238000005096 rolling process Methods 0.000 description 1
- 238000004062 sedimentation Methods 0.000 description 1
- 239000002699 waste material Substances 0.000 description 1
Images


Landscapes
- Manipulator (AREA)
Abstract
一种用于管道机器人的螺旋驱动机构,包括驱动体和保持体;所述驱动体由驱动体机身、支撑轮架和驱动轮构成;所述保持体由支撑轮架、驱动轮、电机和保持体机身构成;保持体和驱动体之间用联轴器连接。本实用新型改进了螺旋驱动的支撑面少和效率低的缺点,提高了管道机器人的行走效率和过弯能力,简化了机构结构,使控制方便简单,提高了管道机器人在复杂环境下的工作能力。
A screw driving mechanism for a pipeline robot comprises a driving body and a holding body; the driving body is composed of a driving body body, a supporting wheel frame and a driving wheel; the holding body is composed of a supporting wheel frame, a driving wheel, a motor and The holding body is composed of a body; the holding body and the driving body are connected by a coupling. The utility model improves the shortcomings of few supporting surfaces and low efficiency of the screw drive, improves the walking efficiency and bending ability of the pipeline robot, simplifies the mechanism structure, makes the control convenient and simple, and improves the working ability of the pipeline robot in a complex environment .
Description
技术领域technical field
本实用新型涉及一种管道检测与维护的机器人,具体是螺旋驱动式管道机器人,用于工业生产中。The utility model relates to a pipeline inspection and maintenance robot, in particular to a spiral-driven pipeline robot, which is used in industrial production.
背景技术Background technique
目前,随着管道事业的飞速发展,管道内部检测清理问题日益显著。运输管道内壁极易出现老化,裂缝,裂纹,异物附着等问题。但是管道内部环境复杂,各种中小型管道也难以让人通过,传统依靠人工检测的方法不仅效率低下而且难度较高,这样对管道的维修与检测就造成了较大的障碍。由于城市的发展,排污管道中,特别是污水中的大量生活杂物或建筑垃圾混入,加速沉淀、淤积现象的发生,很容易造成人民生命与财产损失,给人民生活与社会经济带来麻烦。因此,一款能够进入内部环境复杂的中小型管道,对管道内壁有清理功能的管道机器人急需产生。At present, with the rapid development of the pipeline business, the problem of internal inspection and cleaning of the pipeline is becoming more and more obvious. The inner wall of the transportation pipeline is prone to aging, cracks, cracks, foreign matter adhesion and other problems. However, the internal environment of the pipeline is complex, and it is difficult for people to pass through various small and medium-sized pipelines. The traditional method of relying on manual inspection is not only inefficient but also difficult, which has caused great obstacles to the maintenance and inspection of the pipeline. Due to the development of the city, a large amount of domestic debris or construction waste is mixed in the sewage pipelines, especially in the sewage, which accelerates the occurrence of sedimentation and siltation, which can easily cause people's lives and property losses, and bring trouble to people's lives and social economy. Therefore, there is an urgent need for a pipeline robot that can enter a small and medium-sized pipeline with complex internal environment and has the function of cleaning the inner wall of the pipeline.
国内外管道机器人的驱动方式大致有以下几种:活塞移动方式、滚动移动方式、履带移动方式、蹆足式移动方式、蠕动移动方式和螺旋推进方式等。The driving methods of pipeline robots at home and abroad are roughly as follows: piston moving method, rolling moving method, crawler moving method, foot moving method, creeping moving method and screw propulsion method.
其中,活塞移动式越障能力和拐弯能力差;滚轮移动式速度快、易转弯,但体积大,结构复杂;履带移动式有较大的附着力、牵引力和越障能力,但体积大结构复杂易侧翻;足腿移动式有较大的附着力、牵引力和越障能力,但移动速度慢、控制复杂;蠕动移动式适应微小管径,越障能力强,但移动速度慢、控制复杂;螺旋移动式可在垂直管道行走,易控制、能耗少,但移动速度慢。Among them, the piston mobile type has poor obstacle surmounting ability and turning ability; the roller mobile type is fast and easy to turn, but has a large volume and a complex structure; the crawler mobile type has large adhesion, traction and obstacle surmounting ability, but is large in size and complex in structure Easy to roll over; the foot-leg mobile type has great adhesion, traction and obstacle-surmounting ability, but the moving speed is slow and the control is complicated; the peristaltic mobile type is suitable for small pipe diameters and has strong obstacle-surmounting ability, but the moving speed is slow and the control is complicated; The spiral mobile type can walk in the vertical pipeline, which is easy to control and consumes less energy, but the moving speed is slow.
这些管道机器人驱动方式的适用范围都有一定的局限性。The scope of application of these pipeline robot driving methods has certain limitations.
实用新型内容Utility model content
本实用新型的目的在于提供水平或者有弯曲的变径管道中能够自适应管道的驱动机构。The purpose of the utility model is to provide a driving mechanism capable of adapting to the pipe in a horizontal or curved reducing pipe.
为达到上述目的,本实用新型采用下述技术方案。In order to achieve the above-mentioned purpose, the utility model adopts the following technical scheme.
本实用新型所述的一种用于管道机器人的螺旋驱动机构,包括驱动体和保持体。A screw driving mechanism for a pipeline robot according to the utility model comprises a driving body and a holding body.
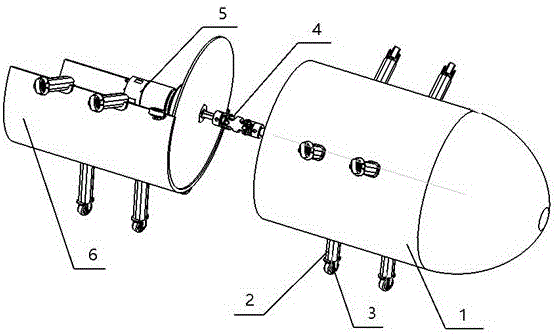
所述驱动体由驱动体机身、支撑轮架和驱动轮构成;驱动体机身与联轴器固定连接;所述支撑轮架为两组,每组三个,共六个,且同一组的三个相邻的支撑轮架的轴线位于同一平面,两两轴线的夹角为120度,固定在驱动体机身上,支撑轮架的另一端分别固定有驱动轮。The driving body is composed of a driving body body, a supporting wheel frame and a driving wheel; the driving body body is fixedly connected with the coupling; the supporting wheel frames are divided into two groups, each group of three, a total of six, and the same group The axes of the three adjacent supporting wheel frames are located on the same plane, and the angle between the two axes is 120 degrees, which are fixed on the body of the driving body, and the other ends of the supporting wheel frames are respectively fixed with driving wheels.
所述保持体由支撑轮架、驱动轮、电机和保持体机身构成;电机与联轴器固定连接;保持体机身与联轴器固定连接;所述支撑轮架为两组,每组三个,共六个,且同一组在与轴线垂直的同一平面且相邻的支撑轮架之间成120度固定在保持体机身上,支撑轮架的另一端分别固定有驱动轮。The holding body is composed of a supporting wheel frame, a driving wheel, a motor and a holding body body; the motor is fixedly connected with the coupling; the holding body body is fixedly connected with the coupling; the supporting wheel frame is divided into two groups, each group Three, a total of six, and the same group is fixed on the holder body at 120 degrees between the same plane perpendicular to the axis and adjacent to the supporting wheel frames, and the other ends of the supporting wheel frames are respectively fixed with driving wheels.
所述保持体和驱动体之间用联轴器连接。电机转动带动驱动体机身转动,保持体上的驱动轮与机身轴线平行,驱动体上的六个驱动轮每前后两个驱动轮在同一条螺旋线上分布,六个共构成三条螺旋线,依靠驱动体上的驱动轮产生的螺旋驱动力推动驱动体和保持体前进。The holding body and the driving body are connected by a coupling. The rotation of the motor drives the body of the driving body to rotate, the driving wheels on the holding body are parallel to the axis of the body, and the six driving wheels on the driving body are distributed on the same spiral line, each of which forms three spiral lines. , relying on the helical driving force generated by the driving wheel on the driving body to push the driving body and the holding body forward.
所述管道机器人的前进螺旋角为27.3度。The forward helix angle of the pipeline robot is 27.3 degrees.
所述管道机器人的联轴器为万向联轴器。The coupling of the pipeline robot is a universal coupling.
所述管道机器人的电机为减速电机。The motor of the pipeline robot is a geared motor.
本实用新型改进了螺旋驱动的支撑面少和效率低的缺点,提高了管道机器人的行走效率和过弯能力,简化了机构结构,使控制方便简单,提高了管道机器人在复杂环境下的工作能力。The utility model improves the shortcomings of few supporting surfaces and low efficiency of the screw drive, improves the walking efficiency and bending ability of the pipeline robot, simplifies the mechanism structure, makes the control convenient and simple, and improves the working ability of the pipeline robot in a complex environment .
附图说明Description of drawings
图1为本实用新型所述装置结构示意图。FIG. 1 is a schematic structural diagram of the device according to the present invention.
图2为本实用新型所述的螺旋驱动方式示意图。FIG. 2 is a schematic diagram of the screw driving mode according to the utility model.
图中:1为驱动体机身、2为支撑轮架、3为驱动轮、4为联轴器、5为电机、6为保持体机身。In the figure: 1 is the driving body, 2 is the supporting wheel frame, 3 is the driving wheel, 4 is the coupling, 5 is the motor, and 6 is the holding body.
具体实施方式Detailed ways
以下结合附图对本实用新型作进一步说明。The present utility model will be further described below in conjunction with the accompanying drawings.
如附图所示,本实用新型提供了一种管道机器人的螺旋驱动机构,包括驱动体和保持体。驱动体由驱动体机身1、支撑轮架2和驱动轮3构成:管道机器人驱动体机身1与联轴器4固定连接;所述六个驱动轮3与六个支撑轮架2分别固定连接,且同一平面相邻的支撑轮架2之间的角度为120度。保持体由支撑轮架2、驱动轮3、电机5和保持体机身1构成:电机5与联轴器4固定连接;管道机器人驱动体机身1与联轴器4固定连接;所述六个驱动轮3与六个支撑轮架2分别固定连接,且同一平面相邻的支撑轮架2之间的角度为120度。保持体和驱动体之间用联轴器4连接。As shown in the accompanying drawings, the utility model provides a screw driving mechanism of a pipeline robot, which includes a driving body and a holding body. The driving body is composed of a
如附图所示,所述的一种适用于管道机器人的螺旋驱动机构,是将螺旋线轨迹直接刻画在驱动体机身1表面,位于不同截面的驱动轮3按照固定规律依次排布在驱动体机身1表面的螺旋线上。当电机5转动,带动驱动体机身1转动使驱动轮3产生的螺旋驱动力推动机器人在管道内部前进。这样的设计保证了机器人驱动体机身拥有多个支撑截面从而提高了其在管道内部的可靠性与稳定性,As shown in the attached drawings, the above-mentioned spiral driving mechanism suitable for a pipeline robot is to directly describe the spiral trajectory on the surface of the
当机器人在有淤泥和污垢的环境中行进时,改进后的驱动方式由于位于第一个截面的驱动轮已经在管壁上开拓出一条螺旋线轨迹,另一截面的驱动轮只需按照已有的轨迹依次前进即可。改进后的驱动方式具有更加省力和效率更高的特点。When the robot travels in an environment with silt and dirt, the improved drive mode has developed a helical trajectory on the tube wall because the drive wheel located in the first section, and the drive wheel of the other section only needs to follow the existing The trajectories can be advanced sequentially. The improved drive method is more labor-saving and more efficient.
Claims (1)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201822178125.XU CN209977571U (en) | 2018-12-25 | 2018-12-25 | Spiral driving mechanism for pipeline robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201822178125.XU CN209977571U (en) | 2018-12-25 | 2018-12-25 | Spiral driving mechanism for pipeline robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN209977571U true CN209977571U (en) | 2020-01-21 |
Family
ID=69250708
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201822178125.XU Expired - Fee Related CN209977571U (en) | 2018-12-25 | 2018-12-25 | Spiral driving mechanism for pipeline robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN209977571U (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN109538878A (en) * | 2018-12-25 | 2019-03-29 | 南昌大学 | A kind of screw drives mechanism for pipe robot |
| CN112829847A (en) * | 2021-03-17 | 2021-05-25 | 湖北工业大学 | A flexible spiral tube crawling device |
-
2018
- 2018-12-25 CN CN201822178125.XU patent/CN209977571U/en not_active Expired - Fee Related
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN109538878A (en) * | 2018-12-25 | 2019-03-29 | 南昌大学 | A kind of screw drives mechanism for pipe robot |
| CN112829847A (en) * | 2021-03-17 | 2021-05-25 | 湖北工业大学 | A flexible spiral tube crawling device |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN103697285B (en) | A kind of wheel carries out compound radial adjustable pipeline robot | |
| CN206632074U (en) | A kind of Novel stretchable pipeline cleaning machine people | |
| CN107061926B (en) | A kind of push-and-pull self-locking pipeline is interior to detect robot | |
| CN207308503U (en) | A kind of pipeline cleaning robot for being suitable for different tube diameters change | |
| CN211343019U (en) | An intelligent dredging robot for small-diameter tunnel drainage blind pipes | |
| CN202156471U (en) | Sucked type pneumatic wall-climbing robot | |
| CN112044884A (en) | A kind of cable duct dredging and cleaning robot | |
| CN110227695A (en) | Adapt to the cleaning apparatus for pipes of different tube diameters | |
| CN102278566A (en) | Microminiature pipeline patrol robot | |
| CN203010110U (en) | Pipe robot | |
| CN108953840A (en) | A kind of cable-free type pipeline robot suitable for different tube diameters | |
| CN206018142U (en) | A kind of pipeline cleaning detects robot | |
| CN220186211U (en) | Crawler-type sewage pipeline robot | |
| CN115162497A (en) | Automatic intelligent robot that dredges of municipal works blowdown sewer | |
| CN210230901U (en) | Pipe cleaning device suitable for different pipe diameters | |
| CN204715264U (en) | The universal brush of tunnel cleaning vehicle | |
| CN107940166A (en) | Inner-walls of duct defect image with spiral pushing device obtains robot | |
| CN202140741U (en) | A Miniature Pipeline Inspection Robot | |
| CN213194915U (en) | A pipe cleaning device | |
| CN219093021U (en) | Mobile non-destructive dredging device | |
| CN216823241U (en) | Spiral wheel set stair-climbing cleaning trolley based on thread fit principle | |
| CN203420357U (en) | Sewer inwall cleaning device | |
| CN109538878A (en) | A kind of screw drives mechanism for pipe robot | |
| CN222999311U (en) | Pipeline dredging device for water pollution control in water conservancy projects | |
| CN212176031U (en) | A municipal pipeline dredging equipment |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20200121 Termination date: 20201225 |