CN203457509U - Intelligent all-dimensional mechanical weeding machine of orchards - Google Patents
Intelligent all-dimensional mechanical weeding machine of orchards Download PDFInfo
- Publication number
- CN203457509U CN203457509U CN201320412761.9U CN201320412761U CN203457509U CN 203457509 U CN203457509 U CN 203457509U CN 201320412761 U CN201320412761 U CN 201320412761U CN 203457509 U CN203457509 U CN 203457509U
- Authority
- CN
- China
- Prior art keywords
- inter
- weeding
- hydraulic
- row
- lateral adjustment
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images


Landscapes
- Soil Working Implements (AREA)
Abstract
本实用新型为一种果园智能化全方位机械除草机,主要包括除草装置、检测控制装置、横向调节装置。所述除草装置包括行间除草装置、株间除草装置,主要由机架、动力传动部分、变速器、车轮、除草刀具组成,用于果树行间和株间杂草的清除;所述检测控制装置包括控制器、横向调节检测红外传感器、速度传感器、树干位置检测红外传感器,用于采集株间除草装置的相对位置信息并处理生成控制指令,控制株间除草装置的运动状态;所述横向调节装置包括横向调节液压机构、横向调节液压机构电磁阀,用于控制株间除草装置的横向偏移。本实用新型通过智能检测控制装置,实现了果树行间和株间杂草的自动清除,解放了劳动力,提高了作业效率。
The utility model relates to an intelligent all-round mechanical weeder for orchards, which mainly includes a weeding device, a detection control device and a lateral adjustment device. The weeding device includes an inter-row weeding device and an inter-row weeding device, which are mainly composed of a frame, a power transmission part, a transmission, a wheel, and a weeding cutter, and are used to remove weeds between rows and rows of fruit trees; the detection and control device It includes a controller, a lateral adjustment detection infrared sensor, a speed sensor, and a trunk position detection infrared sensor, which are used to collect relative position information of the inter-row weeding device and process and generate control instructions to control the motion state of the inter-row weeding device; the lateral adjustment device It includes a horizontal adjustment hydraulic mechanism and a solenoid valve of the horizontal adjustment hydraulic mechanism, which are used to control the lateral offset of the inter-row weeding device. The utility model realizes the automatic removal of weeds between rows and rows of fruit trees through the intelligent detection and control device, liberates the labor force and improves the operation efficiency.
Description
一、技术领域:本实用新型涉及果园管理机械,特别涉及一种果园智能化全方位机械除草机,属于农业机械领域。 1. Technical field: The utility model relates to orchard management machinery, in particular to an orchard intelligent all-round mechanical weeder, which belongs to the field of agricultural machinery. the
二、背景技术: 2. Background technology:
目前,农业生产活动中常用的杂草控制方法主要有人工除草、化学药剂除草、电力除草、机械除草几种形式。 At present, the weed control methods commonly used in agricultural production activities mainly include manual weeding, chemical weeding, electric weeding, and mechanical weeding. the
人工除草作业效率低,劳动强度大,作业成本高,极不适应目前大面积农田杂草的及时防治。 Manual weeding has low efficiency, high labor intensity, and high operating cost, which is extremely unsuitable for the timely control of weeds in large areas of farmland. the
化学药剂除草简单易行、工作效率高,近半个世纪以来,发展迅速,除草剂的品种也越来越多,但是该种除草方式存在残留毒性的积累,会造成严重的环境污染,影响作物的生长。 Chemical weeding is simple and easy to do, with high work efficiency. In the past half century, it has developed rapidly, and there are more and more varieties of herbicides. However, the accumulation of residual toxicity in this weeding method will cause serious environmental pollution and affect crops. growth. the
电力除草技术的基本原理是使电流从杂草内部通过,使杂草的细胞组织破坏导致死亡,该种除草方式能够消除各种杂草,但是电力除草机械电压高,消耗功率大,安全性差。 The basic principle of electric weeding technology is to let electric current pass through the inside of weeds to destroy the cell tissue of weeds and lead to death. This weeding method can eliminate all kinds of weeds, but the mechanical voltage of electric weeding is high, the power consumption is large, and the safety is poor. the
机械除草由于采用机械式除草措施,对农作物生长有很好的促进作用,同时有利于保护生态环境,避免了化学药剂除草造成的农药残留,因此,近年来,该种除草方式受到越来越多的重视。 Due to the use of mechanical weeding measures, mechanical weeding can promote the growth of crops, and at the same time help protect the ecological environment and avoid pesticide residues caused by chemical weeding. Therefore, in recent years, this weeding method has received more and more attention. attention. the
在果树种植过程中,由于果园环境杂草丛生,导致果实的产量和品质急剧下降,因此必须进行杂草控制。在果园特殊环境中,杂草的控制主要分为行间杂草控制和株间杂草控制,由于株间杂草控制必须避开果树进行,传统的除草机械很难应付。现有的果园除草机械只能单独进行株间或行间除草作业,机械化水平低,并且由行走机械牵引的果园智能除草机研究甚少,还处于刚刚起步阶段。 In the process of planting fruit trees, due to the overgrown weeds in the orchard environment, the yield and quality of the fruit will drop sharply, so weed control must be carried out. In the special environment of orchards, weed control is mainly divided into inter-row weed control and inter-row weed control. Since inter-row weed control must avoid fruit trees, traditional weeding machinery is difficult to deal with. Existing orchard weeding machines can only perform inter-plant or inter-row weeding operations alone, and the level of mechanization is low, and there is little research on orchard intelligent weeding machines towed by walking machinery, which is still in its infancy. the
三、发明内容: 3. Contents of the invention:
1、发明目的:为了克服现有除草机械的不足,满足果园高效标准除草技术的要求,本实用新型提供了一种果园智能化全方位机械除草机,其目的是采用智能化机械除草装备,实现果树行间和株间杂草的同时清除,避免化学药剂对环境的污染,提高果园除草的作业效率,解放劳动力。 1. Purpose of the invention: In order to overcome the shortcomings of existing weeding machinery and meet the requirements of high-efficiency standard weeding technology in orchards, the utility model provides an intelligent all-round mechanical weeding machine for orchards. The purpose is to use intelligent mechanical weeding equipment to realize Weeds can be removed between the rows of fruit trees and between the trees at the same time, avoiding the pollution of the environment by chemical agents, improving the efficiency of weeding in the orchard, and liberating the labor force. the
2、技术方案:本实用新型是按照以下技术方案实施的:一种果园智能化全方位机械除草机,包括行间除草装置、株间除草装置、检测控制装置、横向调节装置;所述行间除草装置主要包括三点悬挂机构1、传动轴2、行间除草机构变速器3、行间除草刀具19、行间除草机构机架20、高度调节左右车轮16和21,行间除草机构机架20前端固定有三点悬挂机构1,除草机通过三点悬挂机构1与行走机械连接,由行走机械牵引除草机前进,行间除草机构机架20后端左右两侧安装有高度调节左右车轮16和21,用于控制行间除草机构的作业高度,传动轴2将行走机械后轴输出动力传递给行间除草机构变速器3,行间除草机构变速器3将输入的动力转换后驱动行间除草刀具19旋转,从而实施行间除草作业;所述株间除草装置主要包括液压马达电磁阀7、液压马达8、株间除草机构机架9、株间除草机构变速器13、株间除草刀具14,株间除草机构机架9通过横向调节液压机构10与行间除草机构机架20连接,所述液压马达8一端与行走机械液压输出点相连,另一端与万向节11连接,液压马达电磁阀7与控制器5相连,液压马达电磁阀7接收控制器5的控制指令,控制行走机械液压输出点对液压马达的液压动力输出状态,从而控制液压马达8,液压马达8通过万向节11给株间除草机构变速器13提供动力,株间除草机构变速器13将动力转换后驱动株间除草刀具14旋转,从而实施株间除草作业;所述检测控制装置主要包括电瓶4、控制器5、横向调节检测红外传感器6、速度传感器17、树干位置检 测红外传感器24,控制器5安装在行间除草机构机架20的中间位置,由电瓶4提供电力,横向调节检测红外传感器6安装在株间除草机构机架9的前方,主要检测株间除草机构与前方树干的距离,速度传感器17安装在高度调节左车轮16上,主要检测除草机的行走速度,树干位置检测红外传感器24安装在行间除草机构机架20的前侧方,主要检测行间除草机架20与侧方树干的距离,横向调节检测红外传感器6、速度传感器17和树干位置检测红外传感器24与控制器5连接,控制器5接收横向调节检测红外传感器6、速度传感器17、树干位置检测红外传感器24的检测信息,运行控制算法,生成控制指令;所述横向调节装置主要包括横向调节液压机构10、横向调节液压机构电磁阀22,横向调节液压机构10安装在横向调节液压机构底座23上,横向调节液压机构10一端与行走机械液压输出点相连,另一端固定在株间除草机构机架9上,横向调节液压机构10与横向调节液压机构电磁阀22相连,横向调节液压机构电磁阀22与控制器5相连,横向调节液压机构电磁阀22接收控制器5生成的控制指令,控制横向调节液压机构10的横向运动状态,从而可以实现株间除草装置依据果树位置和树干直径信息,生成对应的运动路径。
2. Technical solution: The utility model is implemented according to the following technical solution: an intelligent all-round mechanical weeder for orchards, including an inter-row weeding device, an inter-row weeding device, a detection control device, and a horizontal adjustment device; the inter-row The weeding device mainly includes a three-point suspension mechanism 1, a
3、优点及效果:本实用新型通过智能检测控制装置自动检测株间除草装置的相对位置信息,生成控制指令,借助于横向调节装置,智能调节株间除草装置的横向偏移量和运行路径,可以适应不同的果园环境,实现了果树行间和株间杂草的机械清除,避免了化学药剂对环境的污染,提高了作业效率,解放了劳动力。 3. Advantages and effects: The utility model automatically detects the relative position information of the inter-row weeding device through the intelligent detection and control device, generates control instructions, and intelligently adjusts the lateral offset and running path of the inter-row weeding device by means of the horizontal adjustment device. It can adapt to different orchard environments, realize the mechanical removal of weeds between rows and rows of fruit trees, avoid environmental pollution by chemical agents, improve operating efficiency, and liberate labor. the
四、附图说明; 4. Description of drawings;
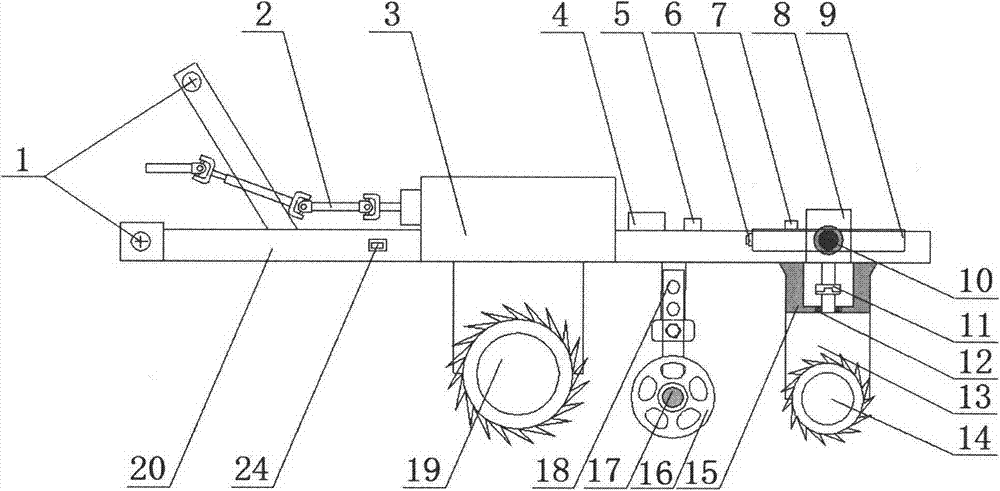
图1为本实用新型果园智能化全方位机械除草机的主视图。 Fig. 1 is the front view of the utility model orchard intelligent all-round mechanical weeder. the
图2为本实用新型果园智能化全方位机械除草机的俯视图。 Fig. 2 is the top view of the utility model orchard intelligent all-round mechanical weeder. the
图3为本实用新型株间除草机构的运动轨迹图。 Fig. 3 is a motion track diagram of the inter-row weeding mechanism of the present invention. the
标注:1-三点悬挂机构;2-传动轴;3-行间除草机构变速器;4-电瓶;5-控制器;6-横向调节检测红外传感器;7-液压马达电磁阀;8-液压马达;9-株间除草机构机架;10-横向调节液压机构;11-万向节;12-轴承;13-株间除草机构变速器;14-株间除草刀具;15-液压马达固定座;16-高度调节左车轮;17-速度传感器;18-高度调节车轮定位孔;19-行间除草刀具;20-行间除草机构机架;21-高度调节右车轮;22-横向调节液压机构电磁阀;23-横向调节液压机构底座;24-树干位置检测红外传感器;25-株间除草机构中心运动轨迹;26-果树。 Marking: 1-three-point suspension mechanism; 2-transmission shaft; 3-interrow weeding mechanism transmission; 4-battery; 5-controller; 6-horizontal adjustment detection infrared sensor; 7-hydraulic motor solenoid valve; 8-hydraulic motor ; 9- frame of inter-plant weeding mechanism; 10- horizontal adjustment hydraulic mechanism; 11- universal joint; 12- bearing; 13- inter-plant weeding mechanism transmission; 14- inter-plant weeding cutter; -Height adjustment left wheel; 17-Speed sensor; 18-Height adjustment wheel positioning hole; 19-Interrow weeding cutter; 20-Interrow weeding mechanism frame; 21-Height adjustment right wheel; ; 23-horizontal adjustment hydraulic mechanism base; 24-trunk position detection infrared sensor; 25-center movement track of weeding mechanism between plants; the
五、具体实施方式: 5. Specific implementation methods:
下面结合附图对本实用新型做更进一步的说明: Below in conjunction with accompanying drawing, the utility model is described further:
如图1和图2所示,一种果园智能化全方位机械除草机结构简图,包括行间除草装置、株间除草装置、检测控制装置、横向调节装置;所述行间除草装置包括三点悬挂机构1、传动轴2、行间除草机构变速器3、高度调节车轮定位孔18、行间除草刀具19、行间除草机构机架20、高度调节左右车轮16和21,行间除草机构机架20前端固定有三点悬挂机构1,除草机通过三点悬挂机构1与行走机械连接,由行走机械牵引除草机前进,行间除草机构机架20后端左右两侧安装有高度调节左右车轮16和21,通过高度调节车轮定位孔18,控制除草机的作业高度,传动轴2将行走机械后轴输出动力传递给行间除草机构变速器3,行间除草机构变速器3将输入的动力转换后驱动行间除草刀具19旋转,从而实施行间除草作业;所述株间除草装置包括液压马达电磁阀7、液压马达8、株间除草机构机架9、万向节11、轴承12、株间除草机构变速器13、株间除草刀具14、液压马达固定座15,株间除草机构机架9通过横向调节液压机构10与行间除草机构机架20连接,所述液压马达8安装在液压马达固定座15中, 液压马达8一端与行走机械液压输出点相连,另一端与万向节11连接,液压马达电磁阀7与控制器5相连,液压马达电磁阀7接收控制器5的控制指令,控制行走机械液压输出点对液压马达的液压动力输出状态,从而控制液压马达8,液压马达8另一端通过万向节11、轴承12与株间除草机构变速器13连接,给株间除草机构变速器13提供动力,株间除草机构变速器13将动力转换后驱动株间除草刀具14旋转,从而实施株间除草作业。所述检测控制装置主要包括电瓶4、控制器5、横向调节检测红外传感器6、速度传感器17、树干位置检测红外传感器24,控制器5安装在行间除草机构机架20的中间位置,由电瓶4提供电力,横向调节检测红外传感器6安装在株间除草机构机架9的前方,主要检测株间除草机构与前方树干的距离,速度传感器17安装在高度调节左车轮16上,主要检测除草机的行走速度,树干位置检测红外传感器24安装在行间除草机构机架20的前侧方,主要检测行间除草机架20与侧方树干的距离,横向调节检测红外传感器6、速度传感器17和树干位置检测红外传感器24与控制器5连接,控制器5接收横向调节检测红外传感器6、速度传感器17、树干位置检测红外传感器24的检测信息,运行控制算法,生成控制指令;所述横向调节装置主要包括横向调节液压机构10、横向调节液压机构电磁阀22,横向调节液压机构底座23,横向调节液压机构10安装在横向调节液压机构底座23上,横向调节液压机构10一端与行走机械液压输出点相连,另一端固定在株间除草机构机架9上,横向调节液压机构10与横向调节液压机构电磁阀22相连,横向调节液压机构电磁阀22与控制器5相连,横向调节液压机构电磁阀22接收控制器5生成的控制指令,控制横向调节液压机构10的横向运动状态,从而可以实现株间除草装置依据果树位置和树干直径信息,生成对应的运动路径。
As shown in Fig. 1 and Fig. 2, a kind of orchard intelligent all-round mechanical weeding machine structure schematic diagram, comprises inter-row weeding device, inter-row weeding device, detection control device, horizontal adjustment device; described inter-row weeding device includes three Point suspension mechanism 1,
如图3所示,一种果园智能化全方位机械除草机株间除草机构运动轨迹, 控制器5根据树干位置检测红外传感器24检测到的距离信息,生成控制指令,控制横向调节液压机构10的收缩运动量,实现株间除草装置依据果树26的位置和树干直径,生成对应的运动轨迹25,缩短了株间除草装置的运行路径,提高了作业效率。
As shown in Figure 3, a kind of orchard intelligent all-round mechanical weeding machine inter-row weeding mechanism movement trajectory,
本实用新型所述一种果园智能化全方位机械除草机,其工作过程如下: An intelligent all-round mechanical weeder for orchards described in the utility model, its working process is as follows:
除草机工作之前,在控制器5中设置株间除草机构的横向调节阈值和距离树干位置阈值,调整除草机高度调节左右车轮16和21的位置,通过三点悬挂机构1放下除草机,打开控制器电源,启动行走装置;除草机工作时,行走机械牵引除草机前进,行间除草装置工作,实施行间除草,横向调节装置将株间除草机构伸入果树株间,实施株间除草,当横向调节检测红外传感器6检测到的株间除草装置与树干距离达到预先设定的横向调节阈值时,株间除草机构根据控制器5的控制指令,自动返回到相应的位置,当树干位置检测红外传感器24检测到的距离大于距离树干位置阈值时,株间除草装置伸出,进入下一株间进行除草作业,此过程进行时,行间除草装置不间断工作,循环进行直至完成所有除草作业;除草机工作结束后,收回株间除草机构,由三点悬挂装置1提升除草机,关闭电源。
Before the weeder works, set the lateral adjustment threshold and the distance from the trunk position threshold of the inter-plant weeding mechanism in the
Claims (5)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201320412761.9U CN203457509U (en) | 2013-07-06 | 2013-07-06 | Intelligent all-dimensional mechanical weeding machine of orchards |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201320412761.9U CN203457509U (en) | 2013-07-06 | 2013-07-06 | Intelligent all-dimensional mechanical weeding machine of orchards |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN203457509U true CN203457509U (en) | 2014-03-05 |
Family
ID=50169894
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201320412761.9U Expired - Fee Related CN203457509U (en) | 2013-07-06 | 2013-07-06 | Intelligent all-dimensional mechanical weeding machine of orchards |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN203457509U (en) |
Cited By (17)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103329653A (en) * | 2013-07-06 | 2013-10-02 | 西北农林科技大学 | Intelligent all-dimensional mechanical weeding machine of orchards |
| CN105706751A (en) * | 2016-04-11 | 2016-06-29 | 苏州宏奇锐自动化有限公司 | Green belt shearing device |
| CN105746192A (en) * | 2016-03-30 | 2016-07-13 | 苏州亚思科精密数控有限公司 | Pruning device for green belts with obstacles |
| CN105746191A (en) * | 2016-03-30 | 2016-07-13 | 苏州亚思科精密数控有限公司 | Green belt trimming device |
| CN105746195A (en) * | 2016-04-11 | 2016-07-13 | 苏州宏奇锐自动化有限公司 | Barrier green belt trimming device |
| CN105766401A (en) * | 2016-04-11 | 2016-07-20 | 苏州宏奇锐自动化有限公司 | Obstructed highway greenbelt pruning system |
| CN105794501A (en) * | 2016-04-11 | 2016-07-27 | 苏州宏奇锐自动化有限公司 | Highway greenbelt trimming device |
| CN105794500A (en) * | 2016-04-11 | 2016-07-27 | 苏州宏奇锐自动化有限公司 | Intelligent green belt pruning device |
| CN105794499A (en) * | 2016-03-30 | 2016-07-27 | 苏州亚思科精密数控有限公司 | Pruning method of green belt pruning machine |
| CN105830754A (en) * | 2016-03-30 | 2016-08-10 | 苏州亚思科精密数控有限公司 | Obstructed greenbelt trimming method |
| CN105850527A (en) * | 2016-03-30 | 2016-08-17 | 苏州亚思科精密数控有限公司 | Pruning system for green belt with obstacles |
| CN105850526A (en) * | 2016-03-30 | 2016-08-17 | 苏州亚思科精密数控有限公司 | Pruning system for green belt |
| CN106376251A (en) * | 2016-11-08 | 2017-02-08 | 宁夏智源农业装备有限公司 | Intelligent weeding machine for Chinese wolfberry |
| CN106304861B (en) * | 2016-10-19 | 2019-02-19 | 宁夏智源农业装备有限公司 | Grape intelligence weeder |
| AT520294B1 (en) * | 2018-02-01 | 2019-03-15 | Agrom Kg | HACK DEVICE |
| CN113907061A (en) * | 2021-09-10 | 2022-01-11 | 东北农业大学 | Intelligent inter-plant weeding equipment based on injury pesticide application method |
| CN116158273A (en) * | 2022-12-07 | 2023-05-26 | 长沙中联重科环境产业有限公司 | Green comprehensive maintenance vehicle |
-
2013
- 2013-07-06 CN CN201320412761.9U patent/CN203457509U/en not_active Expired - Fee Related
Cited By (19)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103329653A (en) * | 2013-07-06 | 2013-10-02 | 西北农林科技大学 | Intelligent all-dimensional mechanical weeding machine of orchards |
| CN105794499A (en) * | 2016-03-30 | 2016-07-27 | 苏州亚思科精密数控有限公司 | Pruning method of green belt pruning machine |
| CN105850526A (en) * | 2016-03-30 | 2016-08-17 | 苏州亚思科精密数控有限公司 | Pruning system for green belt |
| CN105746192A (en) * | 2016-03-30 | 2016-07-13 | 苏州亚思科精密数控有限公司 | Pruning device for green belts with obstacles |
| CN105746191A (en) * | 2016-03-30 | 2016-07-13 | 苏州亚思科精密数控有限公司 | Green belt trimming device |
| CN105850527A (en) * | 2016-03-30 | 2016-08-17 | 苏州亚思科精密数控有限公司 | Pruning system for green belt with obstacles |
| CN105830754A (en) * | 2016-03-30 | 2016-08-10 | 苏州亚思科精密数控有限公司 | Obstructed greenbelt trimming method |
| CN105746195A (en) * | 2016-04-11 | 2016-07-13 | 苏州宏奇锐自动化有限公司 | Barrier green belt trimming device |
| CN105794500A (en) * | 2016-04-11 | 2016-07-27 | 苏州宏奇锐自动化有限公司 | Intelligent green belt pruning device |
| CN105794501A (en) * | 2016-04-11 | 2016-07-27 | 苏州宏奇锐自动化有限公司 | Highway greenbelt trimming device |
| CN105766401A (en) * | 2016-04-11 | 2016-07-20 | 苏州宏奇锐自动化有限公司 | Obstructed highway greenbelt pruning system |
| CN105706751A (en) * | 2016-04-11 | 2016-06-29 | 苏州宏奇锐自动化有限公司 | Green belt shearing device |
| CN106304861B (en) * | 2016-10-19 | 2019-02-19 | 宁夏智源农业装备有限公司 | Grape intelligence weeder |
| CN106376251A (en) * | 2016-11-08 | 2017-02-08 | 宁夏智源农业装备有限公司 | Intelligent weeding machine for Chinese wolfberry |
| AT520294B1 (en) * | 2018-02-01 | 2019-03-15 | Agrom Kg | HACK DEVICE |
| AT520294A4 (en) * | 2018-02-01 | 2019-03-15 | Agrom Kg | HACK DEVICE |
| US11627693B2 (en) | 2018-02-01 | 2023-04-18 | Roman ROMSTORFER | Hoeing device |
| CN113907061A (en) * | 2021-09-10 | 2022-01-11 | 东北农业大学 | Intelligent inter-plant weeding equipment based on injury pesticide application method |
| CN116158273A (en) * | 2022-12-07 | 2023-05-26 | 长沙中联重科环境产业有限公司 | Green comprehensive maintenance vehicle |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN103329653B (en) | A kind of intelligent comprehensive weeding by machine in orchard machine | |
| CN102696294B (en) | Weeding robot with adjustable center of gravity for paddy fields | |
| CN103404379B (en) | Self-propelled intelligent flower thinning machine for orchard | |
| CN104904700B (en) | A kind of comprehensive weeder of intelligent crops and method | |
| CN103314689B (en) | A kind of self-navigation orchard intelligence ditching-fertilizing machine | |
| CN203369088U (en) | Intelligent ditching fertilizer distributor for garden based on automatic navigation | |
| CN111758424A (en) | A field cotton automatic topping device | |
| CN101412217A (en) | Autonomous field robot | |
| CN113678587B (en) | An unmanned rice intertillage weeder and its operation method | |
| CN204722111U (en) | The comprehensive weeder of a kind of intelligent crops | |
| CN103314663A (en) | Intelligentized intra-row and intra-plant weeding device for crops in seedling stage | |
| CN102792943A (en) | Multispectral vision based efficient weeding robot | |
| CN107600202A (en) | A kind of intelligent weed-eradicating robot for being applicable complicated landform | |
| CN103416251B (en) | A kind of plant cultivation trolley and control method thereof | |
| CN117356245B (en) | Intelligent ridge mowing robot structure and autonomous navigation and mowing operation control method thereof | |
| CN111066386A (en) | An interplant weeding device based on machine vision | |
| CN107509399A (en) | A kind of green intelligent weed-eradicating robot | |
| CN206260441U (en) | Mobile sprinkling irrigation equipment | |
| KR102356045B1 (en) | Weedkiller robot | |
| CN102124847B (en) | Electric stepping rice transplanter | |
| CN204560721U (en) | High precision automatic pesticide spraying machine | |
| CN207269304U (en) | A kind of green intelligent weed-eradicating robot | |
| CN113907061A (en) | Intelligent inter-plant weeding equipment based on injury pesticide application method | |
| CN204498988U (en) | A kind of drone version treegarden irrigation machine | |
| CN106922238B (en) | An intelligent agricultural machinery automatic alignment device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20140305 Termination date: 20140706 |
|
| EXPY | Termination of patent right or utility model |