CN203033287U - Automatic transfer bin of production line - Google Patents

Automatic transfer bin of production line Download PDF

Info

Publication number
CN203033287U
CN203033287U CN201220742086.1U CN201220742086U CN203033287U CN 203033287 U CN203033287 U CN 203033287U CN 201220742086 U CN201220742086 U CN 201220742086U CN 203033287 U CN203033287 U CN 203033287U
Authority
CN
China
Prior art keywords
stacker
track
warehouse
carrier
production line
Prior art date
Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
Expired - Lifetime
Application number
CN201220742086.1U
Other languages
Chinese (zh)
Inventor
梁子宇
杨杰麟
梁谦
Current Assignee (The listed assignees may be inaccurate. Google has not performed a legal analysis and makes no representation or warranty as to the accuracy of the list.)
Guangxi Sanwei Home New Material Co ltd
Original Assignee
GUANGXI SUNWAY FOREST PRODUCTS INDUSTRY Co Ltd
Priority date (The priority date is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the date listed.)
Filing date
Publication date
Application filed by GUANGXI SUNWAY FOREST PRODUCTS INDUSTRY Co Ltd filed Critical GUANGXI SUNWAY FOREST PRODUCTS INDUSTRY Co Ltd
Priority to CN201220742086.1U priority Critical patent/CN203033287U/en
Application granted granted Critical
Publication of CN203033287U publication Critical patent/CN203033287U/en
Anticipated expiration legal-status Critical
Expired - Lifetime legal-status Critical Current

Links

Images

Classifications

    • YGENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
    • Y02TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
    • Y02PCLIMATE CHANGE MITIGATION TECHNOLOGIES IN THE PRODUCTION OR PROCESSING OF GOODS
    • Y02P90/00Enabling technologies with a potential contribution to greenhouse gas [GHG] emissions mitigation
    • Y02P90/02Total factory control, e.g. smart factories, flexible manufacturing systems [FMS] or integrated manufacturing systems [IMS]

Landscapes

  • Warehouses Or Storage Devices (AREA)

Abstract

本实用新型公开了一种生产线自动化中转仓,涉及林产化工技术领域,尤其是一种板材生产线自动化中转仓,包括有行走在生产线通道上的运输车,所述运输车上设有车上堆垛车轨道和车上堆垛车位置传感器,在所述运输车的轨道的至少一侧设有多条用于与所述车上堆垛车轨道对接的仓库堆垛车轨道,在所述车上堆垛车轨道或所述仓库堆垛车轨道上有一辆堆垛车;在所述生产线通道上设有检测所述运输车在轨道上的位置的运输车位置传感器,每条仓库堆垛车轨道均装有检测所述堆垛车在所述仓库堆垛车轨道上的位置的堆垛车位置传感器。本实用新型可以解决生产线中转仓空间利用率不高,生产效率低的问题。

Figure 201220742086

The utility model discloses an automatic transfer warehouse for a production line, which relates to the technical field of forestry chemical industry, in particular to an automatic transfer warehouse for a plate production line, which includes a transport vehicle walking on the production line channel, and the transport vehicle is provided with on-vehicle stacking Vehicle track and on-vehicle stacker position sensor, at least one side of the track of the transport vehicle is provided with a plurality of warehouse stacker tracks for docking with the on-vehicle stacker track, on the vehicle There is a stacker truck on the stacker truck track or the warehouse stacker truck track; a transporter position sensor that detects the position of the transporter on the track is provided on the production line channel, and each warehouse stacker truck track All are equipped with a stacker position sensor that detects the position of the stacker on the track of the warehouse stacker. The utility model can solve the problems of low space utilization rate and low production efficiency of the transfer warehouse of the production line.

Figure 201220742086

Description

Roll-over in the production line automation
Technical field
The utility model relates to the forest chemical technical field, roll-over in especially a kind of panel production line automation.
Background technology
Middle roll-over originally is that because the restriction of fork truck itself, so the interval of two storage locations is wideer, the height that sheet material is stacked is not very high with the main tool of fork truck as transportation and stacking, and this just causes the space availability ratio in warehouse not high.And with artificial memory board material, to the specification of sheet material, management of information such as date manufactured will spend a large amount of time, so just cause the low problem of production efficiency.
The utility model content
The purpose of this utility model provides roll-over in a kind of panel production line automation, can make stacking process realize automation, and it is not high that it can solve the warehouse space degree of utilization, the problem that production efficiency is low.
In order to address the above problem, the technical solution adopted in the utility model is: roll-over in this all production line automation, include the transport trolley of walking on the manufacturing line passage, described transport trolley is provided with on the car carrier-and-stacker position transduser on the carrier-and-stacker track and car, at least one side of the track of described transport trolley be provided with many be used for described car on the warehouse carrier-and-stacker track of carrier-and-stacker orbital docking, carrier-and-stacker track or described warehouse carrier-and-stacker track have a carrier-and-stacker on described car; Be provided with the transport trolley position transduser that detects described transport trolley position in orbit at described manufacturing line passage, every warehouse carrier-and-stacker track all is equipped with the carrier-and-stacker position transduser that detects the position of described carrier-and-stacker on described warehouse carrier-and-stacker track; Carrier-and-stacker position transduser on the described car, the signal of described transport trolley position transduser and described carrier-and-stacker position transduser are fed to the programming controller of a described transport trolley of control and described carrier-and-stacker.
In the technique scheme, more specifically scheme can also be: described transport trolley position transduser is made of the transport trolley beam reflection plate that is located at described transport trolley track one end and the laser rangefinder that is located at the described transport trolley beam reflection plate of aiming on the described transport trolley; Described carrier-and-stacker position transduser is made of the carrier-and-stacker beam reflection plate that is located at described warehouse carrier-and-stacker track one end and the laser rangefinder that is located at the described carrier-and-stacker beam reflection plate of aiming on the described carrier-and-stacker.
Owing to adopted technique scheme, the utility model compared with prior art, the beneficial effect that has is:
1, owing to adopted the transport trolley of automatic control and carrier-and-stacker to load and unload and transport sheet material, the stacking height of each storage location can reach 5 meters, the interval of two storage locations has only 80 centimetres, distance between two row has only 1 meter, so improved the space availability ratio in warehouse and improved production efficiency.
2, roll-over adopts programming controller control transport trolley and carrier-and-stacker to store and extract in this production line automation, compare with the middle roll-over of adopting the forklift carrying, can realize the difference access of many specifications, many kinds, and possess automatic memory and writing function, can be according to the specific requirement of the time requirement of goods storage and different cultivars goods to satisfy the transfer needs on the manufacturing line by arranging of access strategy.
Description of drawings
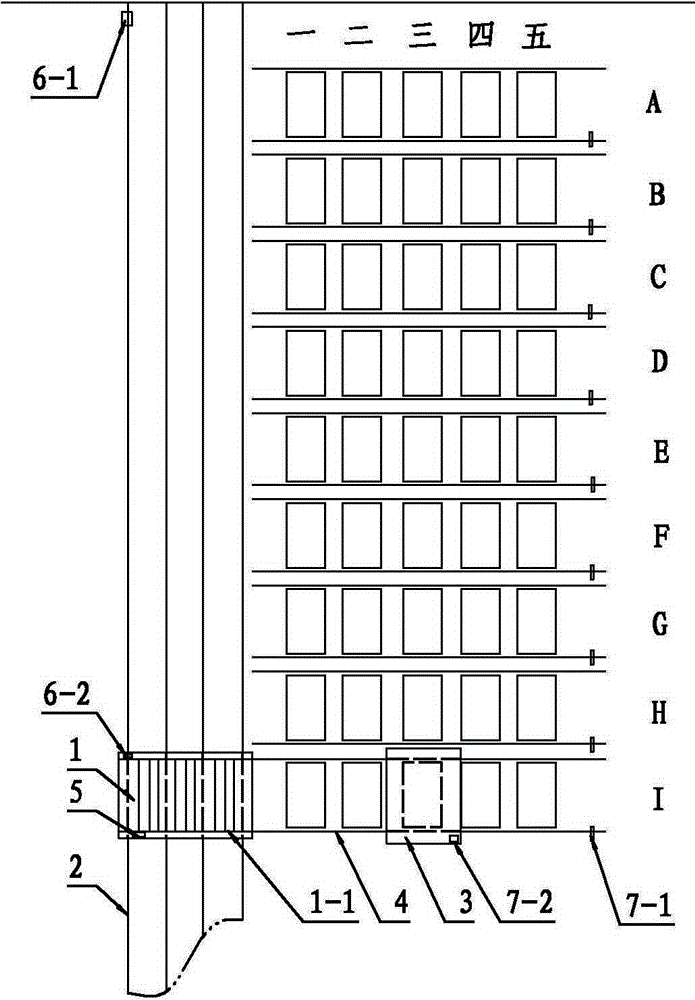
Fig. 1 is the utility model scheme drawing.
The specific embodiment
The utility model is described in further detail below in conjunction with drawings and Examples:
Roll-over in the production line automation of Fig. 1, include the transport trolley 1 of walking on the manufacturing line passage, transport trolley 1 is provided with on the car carrier-and-stacker position transduser 5 on the carrier-and-stacker track 1-1 and car, side at the track 2 of transport trolley 1 is provided with A-I totally 9 firm position positions, each firm position position is provided be made of two one steel rails one and is used for the warehouse carrier-and-stacker track 4 that docks with carrier-and-stacker track 1-1 on the car, every row has one to five totally 5 bin levels, I is capable in the warehouse, a carrier-and-stacker 3 is arranged on the carrier-and-stacker track 4 of the 3rd position in storehouse, be provided with the transport trolley position transduser that detects the position of transport trolley 1 on track 2 at described manufacturing line passage, this transport trolley position transduser is made of the transport trolley beam reflection plate 6-1 that is located at transport trolley track 2 one ends and the laser rangefinder 6-2 that is located at aiming transport trolley beam reflection plate 6-1 on the transport trolley 3; The signal that programming controller provides by these transport trolley position transdusers, can control transport trolley 1 rests on certain carrier-and-stacker track 4 termination, warehouse as required, allow carrier-and-stacker track 1-1 docks with warehouse carrier-and-stacker track 4 on the car on the transport trolley 1, thereby allow carrier-and-stacker 3 travel to and fro between on the car between the carrier-and-stacker track 1-1 and warehouse carrier-and-stacker track 4; Every warehouse carrier-and-stacker track 4 all is equipped with the carrier-and-stacker position transduser that detects the position of carrier-and-stacker 3 on warehouse carrier-and-stacker track 4; These carrier-and-stacker position transdusers are made of the carrier-and-stacker beam reflection plate 7-1 that is located at warehouse carrier-and-stacker track 4 one ends and the laser rangefinder 7-2 that is located at aiming carrier-and-stacker beam reflection plate 7-1 on the carrier-and-stacker 3; Carrier-and-stacker position transduser 5 on the car, the signal of transport trolley position transduser and carrier-and-stacker position transduser are fed to the programming controller of control transport trolley 1 and carrier-and-stacker 3; The signal that programming controller provides by these carrier-and-stacker position transdusers, can control on certain bin level that carrier-and-stacker 3 rests on certain bar warehouse carrier-and-stacker track 4 as required, allow and move between carrier-and-stacker 3 certain bin level in transport trolley 1 and warehouse, with the access goods.
In the time will transporting a lamination to assigned address I three, the programming controller of control transport trolley 1 and carrier-and-stacker 3 receives instruction, receive the feedback signal that is installed in the sensor on transport trolley 1 and the carrier-and-stacker 3 simultaneously, draw the execution signal by the inner intelligent computing of programming controller and judgement, control transport trolley 1 arrives the termination of the house track 4 of I position along track 2 walkings of transport trolley, by the position transduser on the transport trolley 1 signal feedback is arrived controller after arriving assigned address, controller is assigned cutoff command, transport trolley 1 stops, carrier-and-stacker 3 is walked behind three of I from transport trolley 1 track travel to warehouse carrier-and-stacker track 4 and along warehouse carrier-and-stacker track 4, position transduser on the carrier-and-stacker 3 arrives controller to signal feedback, controller is assigned cutoff command, carrier-and-stacker 3 stops, and unloads plate then.

Claims (2)

1.一种生产线自动化中转仓,包括有行走在生产线通道上的运输车(1),其特征在于:所述运输车(1)上设有车上堆垛车轨道(1-1)和车上堆垛车位置传感器(5),在所述运输车的轨道(2)的至少一侧设有多条用于与所述车上堆垛车轨道(1-1)对接的仓库堆垛车轨道(4),在所述车上堆垛车轨道(1-1)或所述仓库堆垛车轨道(4)上有一辆堆垛车(3);在所述生产线通道上设有检测所述运输车(1)在轨道(2)上的位置的运输车位置传感器,每条仓库堆垛车轨道(4)均装有检测所述堆垛车(3)在所述仓库堆垛车轨道(4)上的位置的堆垛车位置传感器;所述车上堆垛车位置传感器(5),所述运输车位置传感器和所述堆垛车位置传感器的信号馈送到一控制所述运输车(1)和所述堆垛车(3)的程序控制器。 1. An automatic transfer warehouse for a production line, including a transport vehicle (1) walking on the production line channel, characterized in that: the transport vehicle (1) is equipped with a stacker track (1-1) on the vehicle and a vehicle The upper stacker position sensor (5), at least one side of the track (2) of the transport vehicle is provided with a plurality of warehouse stackers for docking with the upper stacker track (1-1) track (4), there is a stacker truck (3) on the stacker track (1-1) or the warehouse stacker track (4); The transport vehicle position sensor for the position of the transport vehicle (1) on the track (2), each warehouse stacker track (4) is equipped with a (4) The stacker truck position sensor on the position; the stacker truck position sensor (5) on the truck, the signals of the transporter position sensor and the stacker truck position sensor are fed to a controller that controls the transporter (1) and the program controller of the stacker truck (3). 2.根据权利要求1所述的生产线自动化中转仓,其特征在于:所述运输车位置传感器由设在所述运输车轨道(2)一端的运输车光束反射板(6-1)和设在所述运输车上瞄准所述运输车光束反射板(6-1)的激光测距仪(6-2)构成;所述堆垛车位置传感器由设在所述仓库堆垛车轨道(4)一端的堆垛车光束反射板(7-1)和设在所述堆垛车(3)上瞄准所述堆垛车光束反射板(7-1)的激光测距仪(7-2)构成。 2. The production line automation transfer warehouse according to claim 1, characterized in that: the transport vehicle position sensor is composed of a transport vehicle beam reflector (6-1) installed at one end of the transport vehicle track (2) and The laser rangefinder (6-2) aimed at the beam reflection plate (6-1) of the transport vehicle is composed of a laser range finder (6-2); the position sensor of the stacker is set on the track (4) A stacker truck beam reflection plate (7-1) at one end and a laser range finder (7-2) arranged on the stacker truck (3) to aim at the stacker truck beam reflection plate (7-1) .
CN201220742086.1U 2012-12-31 2012-12-31 Automatic transfer bin of production line Expired - Lifetime CN203033287U (en)

Priority Applications (1)

Application Number Priority Date Filing Date Title
CN201220742086.1U CN203033287U (en) 2012-12-31 2012-12-31 Automatic transfer bin of production line

Applications Claiming Priority (1)

Application Number Priority Date Filing Date Title
CN201220742086.1U CN203033287U (en) 2012-12-31 2012-12-31 Automatic transfer bin of production line

Publications (1)

Publication Number Publication Date
CN203033287U true CN203033287U (en) 2013-07-03

Family

ID=48685424

Family Applications (1)

Application Number Title Priority Date Filing Date
CN201220742086.1U Expired - Lifetime CN203033287U (en) 2012-12-31 2012-12-31 Automatic transfer bin of production line

Country Status (1)

Country Link
CN (1) CN203033287U (en)

Cited By (4)

* Cited by examiner, † Cited by third party
Publication number Priority date Publication date Assignee Title
CN103010649A (en) * 2012-12-31 2013-04-03 广西三威林产工业有限公司 Production line automation transit warehouse
CN104671148A (en) * 2015-02-25 2015-06-03 昆山宝锦激光拼焊有限公司 Stacker
CN104773432A (en) * 2015-04-20 2015-07-15 南京我乐家居制造有限公司 Automatic warehouse output and input device and method of plate production line
CN109720657A (en) * 2017-10-31 2019-05-07 楚天科技股份有限公司 A kind of sterilizing logistics system and sterilizing methods

Cited By (5)

* Cited by examiner, † Cited by third party
Publication number Priority date Publication date Assignee Title
CN103010649A (en) * 2012-12-31 2013-04-03 广西三威林产工业有限公司 Production line automation transit warehouse
CN104671148A (en) * 2015-02-25 2015-06-03 昆山宝锦激光拼焊有限公司 Stacker
CN104773432A (en) * 2015-04-20 2015-07-15 南京我乐家居制造有限公司 Automatic warehouse output and input device and method of plate production line
CN104773432B (en) * 2015-04-20 2017-05-10 南京我乐家居股份有限公司 Automatic warehouse output and input device and method of plate production line
CN109720657A (en) * 2017-10-31 2019-05-07 楚天科技股份有限公司 A kind of sterilizing logistics system and sterilizing methods

Similar Documents

Publication Publication Date Title
CN203714555U (en) Intensive bi-directional child and mother rail guide vehicle automatic storage and fetch warehouse logistics device
TWI804513B (en) Storage and retrieval system
CN103010649A (en) Production line automation transit warehouse
CN104609086B (en) Four-directional shuttle vehicle control system based on road right tokens
CN103171850B (en) Transhipment is arranged in the system of the goods on handling equipment
CN203294644U (en) Intensive bidirectional shuttle vehicle automatic storage and retrieval warehouse logistics device
CN107601062B (en) High-speed rail logistics intelligent loading and unloading system and method based on AGV trolley
CN104724430B (en) A kind of goods yard arrangement method of lineament stereo storage rack
CN206456846U (en) A kind of automatic stereowarehouse
CN110540000A (en) Automatic warehouse storing and taking system with efficient and convenient layout structure
CN107572267B (en) Logistics intelligent loading and unloading system and method
CN103910158B (en) Tobacco shred box goes out to put induction system in storage
KR101240513B1 (en) Multi deep pallet shuttle system and management method for the system
CN107161586A (en) One kind automation filter stick storehouse piler scheduling system
CN104163376A (en) Goods delivering and receiving method of multistoried building and dedicated goods delivering machine thereof
CN102167208A (en) Double-platform stacker applicable to high turnover rate overhead three-dimensional storage system
CN204702079U (en) A kind of classified storage type multilayer logistics warehouse
CN107499812A (en) Control method without tunnel tiered warehouse facility
CN105236057A (en) Automatic book storing and taking device and method
CN108820664A (en) A kind of intelligent warehousing system based on cluster storage robot
CN106743025A (en) One kind goes out base management system
CN104495182B (en) RFID (radio frequency identification)-based two-bin rail-bound conveying vehicle and rail layout and positioning control method
CN107089461A (en) A kind of unmanned storage Special carrier
CN203612549U (en) Bi-directional reciprocating type moving platform
CN207293220U (en) Suitable for the logistics code fetch system of freight container

Legal Events

Date Code Title Description
C14 Grant of patent or utility model
GR01 Patent grant
CP01 Change in the name or title of a patent holder

Address after: 543000 No.81 Tangyuan Road, Wuzhou City, Guangxi Zhuang Autonomous Region

Patentee after: Guangxi Sanwei home new material Co.,Ltd.

Address before: 543000 No.81 Tangyuan Road, Wuzhou City, Guangxi Zhuang Autonomous Region

Patentee before: GUANGXI SUNWAY FOREST PRODUCTS INDUSTRY Co.,Ltd.

CP01 Change in the name or title of a patent holder
CX01 Expiry of patent term

Granted publication date: 20130703

CX01 Expiry of patent term