CN202829333U - Tilt rotation driving mechanism and crane - Google Patents
Tilt rotation driving mechanism and crane Download PDFInfo
- Publication number
- CN202829333U CN202829333U CN 201220449878 CN201220449878U CN202829333U CN 202829333 U CN202829333 U CN 202829333U CN 201220449878 CN201220449878 CN 201220449878 CN 201220449878 U CN201220449878 U CN 201220449878U CN 202829333 U CN202829333 U CN 202829333U
- Authority
- CN
- China
- Prior art keywords
- drum
- tilting
- wire rope
- pulley
- hoisting
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
- 230000007246 mechanism Effects 0.000 title claims abstract description 29
- 238000004804 winding Methods 0.000 claims description 18
- 239000003638 chemical reducing agent Substances 0.000 claims description 10
- 238000000034 method Methods 0.000 description 3
- 229910000831 Steel Inorganic materials 0.000 description 2
- 238000010586 diagram Methods 0.000 description 2
- 230000004048 modification Effects 0.000 description 2
- 238000012986 modification Methods 0.000 description 2
- 239000010959 steel Substances 0.000 description 2
- 230000009471 action Effects 0.000 description 1
- 230000009286 beneficial effect Effects 0.000 description 1
- 230000008859 change Effects 0.000 description 1
- 238000005516 engineering process Methods 0.000 description 1
- 230000006872 improvement Effects 0.000 description 1
- 230000008569 process Effects 0.000 description 1
Images


Landscapes
- Carriers, Traveling Bodies, And Overhead Traveling Cranes (AREA)
Abstract
本实用新型提供的一种倾转驱动机构,包括机架、吊具总成、安装于机架上的左侧起升卷筒和右侧起升卷筒,安装于吊具总成上的两侧的第一左侧滑轮和第一右侧滑轮,第一左侧起升钢丝绳,第一右侧起升钢丝绳。还包括第一倾转卷筒;第一右侧起升钢丝绳绕缠在第一倾转卷筒、第一右侧滑轮、右侧起升卷筒上;第一左侧起升钢丝绳绕缠在第一倾转卷筒、第一左侧滑轮、左侧起升卷筒上。该倾转驱动机构结构简单、稳定性好、控制精度高。本实用新型还提供一种包括所述的倾转驱动机构的起重机。
A tilting driving mechanism provided by the utility model includes a frame, a spreader assembly, a left lifting reel and a right lifting reel installed on the frame, and two lifting reels installed on the spreader assembly. The first left pulley and the first right pulley on the side, the first left hoisting wire rope, and the first right hoisting wire rope. It also includes a first tilting drum; the first right hoisting wire rope is wound on the first tilting drum, the first right pulley, and the right hoisting drum; the first left hoisting wire rope is wound on the On the first tilting drum, the first left pulley, and the left lifting drum. The tilting driving mechanism has the advantages of simple structure, good stability and high control precision. The utility model also provides a crane including the tilting drive mechanism.
Description
技术领域 technical field
本实用新型涉及工程机械技术领域,具体而言,涉及一种倾转驱动机构及起重机。The utility model relates to the technical field of engineering machinery, in particular to a tilting drive mechanism and a crane.
背景技术 Background technique
目前,起重机在抓取集装箱时,因集装箱倾斜放置,使得吊具在与集装箱的锁孔对位时出现困难。特别是,在船舶上抓取集装箱时,由波浪的晃动,也会导致对位困难。因此需要调节吊具总成倾转,实现吊具总成与集装箱对箱,完成装卸集装箱任务。At present, when the crane grabs the container, it is difficult for the spreader to align with the lock hole of the container because the container is placed obliquely. In particular, when grabbing a container on a ship, the shaking of the waves will also cause alignment difficulties. Therefore, it is necessary to adjust the tilting of the spreader assembly to realize alignment between the spreader assembly and the container to complete the task of loading and unloading the container.
现有起重机上的吊具总成的倾转机构大部分采用液压缸或螺杆或电液推杆的直线运动的元件来实现钢丝绳的移动,来改变集装箱吊具上每个滑轮吊点处的钢丝绳长度,进而实现集装箱吊具水平面内的转动,这对于倾转角度小的起重机可以采用;但是随着用户要求的倾转角度加大,导致钢丝绳需要移动的距离就要随之加长,而目前的直线运动元件由于结构尺寸的限制,用起来就会显得体积庞大和笨重,且由于受到直线运动元件的限制,运动速度不能太高,行程受限。无法解决吊具总成大倾转角度对箱问题。Most of the tilting mechanisms of the spreader assembly on the existing cranes use hydraulic cylinders or linear motion elements of screw rods or electro-hydraulic push rods to realize the movement of the wire ropes to change the wire ropes at each pulley lifting point on the container spreader. length, and then realize the rotation of the container spreader in the horizontal plane, which can be used for cranes with small tilt angles; but as the tilt angle required by users increases, the distance that the steel wire rope needs to move will increase accordingly, while the current Due to the limitation of the structural size of the linear motion element, it will appear bulky and cumbersome to use, and due to the limitation of the linear motion element, the movement speed cannot be too high and the stroke is limited. Can not solve the large tilt angle of the spreader assembly to the box.
实用新型内容 Utility model content
为了解决上述技术问题,本实用新型提供了一种倾转驱动机构,包括机架、吊具总成、安装于机架上的左侧起升卷筒和右侧起升卷筒,安装于吊具总成上的两侧的第一左侧滑轮和第一右侧滑轮,第一左侧起升钢丝绳,第一右侧起升钢丝绳。还包括第一倾转卷筒;第一右侧起升钢丝绳绕缠在第一倾转卷筒、第一右侧滑轮、右侧起升卷筒上;第一左侧起升钢丝绳绕缠在第一倾转卷筒、第一左侧滑轮、左侧起升卷筒上;绕缠在第一倾转卷筒上第一右侧起升钢丝绳和第一左侧起升钢丝绳,绕缠方向相反。In order to solve the above technical problems, the utility model provides a tilting drive mechanism, including a frame, a spreader assembly, a left lifting drum and a right lifting drum installed on the frame, The first left pulley and the first right pulley on both sides on the tool assembly, the first left hoisting wire rope, and the first right hoisting wire rope. It also includes a first tilting drum; the first right hoisting wire rope is wound on the first tilting drum, the first right pulley, and the right hoisting drum; the first left hoisting wire rope is wound on the On the first tilting drum, the first left pulley, and the left hoisting drum; the first right hoisting wire rope and the first left hoisting wire rope are wound on the first tilting drum, winding direction on the contrary.
优选地,还包括第二倾转卷筒,安装于吊具总成上两侧的第二左侧滑轮和第二右侧滑轮,第二左侧起升钢丝绳,第二右侧起升钢丝绳;第二右侧起升钢丝绳绕缠在第二倾转卷筒、第二右侧滑轮、右侧起升卷筒上;第二左侧起升钢丝绳绕缠在第二倾转卷筒、第二左侧滑轮、左侧起升卷筒上;绕缠在第二倾转卷筒上第二右侧起升钢丝绳和第二左侧起升钢丝绳,绕缠方向相反。Preferably, it also includes a second tilting drum, a second left pulley and a second right pulley installed on both sides of the spreader assembly, a second left hoisting wire rope, and a second right hoisting wire rope; The second right hoisting wire rope is wound on the second tilting drum, the second right pulley, and the right hoisting drum; the second left side hoisting wire rope is wound on the second tilting drum, the second On the left side pulley and the left side hoisting drum; the second right side hoisting wire rope and the second left side hoisting wire rope are wound on the second tilting drum, and the winding direction is opposite.
优选地,第一右侧滑轮和第一左侧滑轮旋转轴线重合,第二右侧滑轮和第二左侧滑轮旋转轴线重合,该两者旋转轴线以吊具总成中心平面对称设置。Preferably, the rotation axes of the first right pulley and the first left pulley are coincident, the rotation axes of the second right pulley and the second left pulley are coincident, and the rotation axes of the two are arranged symmetrically with respect to the central plane of the spreader assembly.
优选地,还包括导向滑轮,第一倾转卷筒和第二倾转卷筒旋转平面与第一右侧滑轮、第一左侧滑轮、第二右侧滑轮、第二左侧滑轮、左侧起升卷筒、右侧起升卷筒旋转平面垂直;第一右侧起升钢丝绳依次绕缠在第一倾转卷筒、导向滑轮、第一右侧滑轮、右侧起升卷筒上;第一左侧起升钢丝绳依次绕缠在第一倾转卷筒、导向滑轮、第一左侧滑轮、左侧起升卷筒上;第二右侧起升钢丝绳依次绕缠在第二倾转卷筒、导向滑轮、第二右侧滑轮、右侧起升卷筒上;第二左侧起升钢丝绳依次绕缠在第二倾转卷筒、导向滑轮、第二左侧滑轮、左侧起升卷筒上。Preferably, it also includes guide pulleys, the rotation plane of the first tilting drum and the second tilting drum and the first right side pulley, the first left side pulley, the second right side pulley, the second left side pulley, the left side The rotation planes of the hoisting drum and the right hoisting drum are vertical; the first right hoisting wire rope is wound on the first tilting drum, the guide pulley, the first right pulley, and the right hoisting drum in turn; The first left hoisting wire rope is wound on the first tilting drum, the guide pulley, the first left pulley, and the left hoisting drum in turn; the second right hoisting wire rope is wound on the second tilting drum in turn. Drum, guide pulley, second right pulley, right lifting drum; second left lifting wire rope is wound on the second tilting drum, guide pulley, second left pulley, left lift on the liter reel.
优选地,第一右侧起升钢丝绳一端固定在第一倾转卷筒上,另一端固定在右侧起升卷筒上;第二右侧起升钢丝绳一端固定在第二倾转卷筒上,另一端固定在右侧起升卷筒上;第一左侧起升钢丝绳一端固定在第一倾转卷筒上,另一端固定在左侧起升卷筒上;第二左侧起升钢丝绳一端固定在第二倾转卷筒上,另一端固定在左侧起升卷筒上。Preferably, one end of the first right hoisting wire rope is fixed on the first tilting drum, and the other end is fixed on the right hoisting drum; one end of the second right hoisting wire rope is fixed on the second tilting drum , the other end is fixed on the right hoisting drum; one end of the first left hoisting wire rope is fixed on the first tilting drum, and the other end is fixed on the left hoisting drum; the second left hoisting wire rope One end is fixed on the second tilting drum, and the other end is fixed on the left lifting drum.
优选地,还包括用于驱动第一倾转卷筒转动的第一电机、用于驱动第二倾转卷筒转动的第二电机、用于检测第一倾转卷筒转动角度的第一传感器、用于检测第一倾转卷筒转动角度的第二传感器、控制器;控制器获取第一传感器和第二传感器信号,控制第一电机和第二电机旋转。Preferably, it also includes a first motor for driving the rotation of the first tilting drum, a second motor for driving the rotation of the second tilting drum, and a first sensor for detecting the rotation angle of the first tilting drum , a second sensor for detecting the rotation angle of the first tilting drum, and a controller; the controller acquires signals from the first sensor and the second sensor, and controls the rotation of the first motor and the second motor.
优选地,还包括减速机、第一电机通过减速机驱动第一倾转卷筒转动,第二电机通过减速机驱动第二倾转卷筒转动;减速机内设置有制动器,通过制动器对第一倾转卷筒或/和第二倾转卷筒进行制动。Preferably, it also includes a reducer, the first motor drives the first tilting drum to rotate through the reducer, and the second motor drives the second tilting drum to rotate through the reducer; The tilting drum or/and the second tilting drum are braked.
优选地,绕缠在第一倾转卷筒上第一右侧起升钢丝绳和绕缠在第二倾转卷筒上第二右侧起升钢丝绳绕缠方向相同;绕缠在第一倾转卷筒上第一左侧起升钢丝绳和绕缠在第二倾转卷筒上第二左侧起升钢丝绳绕缠方向相同;当操作手需要抓取集装箱,需要调整吊具总成左右高度差时;控制器控制第一电机和第二电机同时正转或反转;当操作手需要调整吊具总成旋转时;控制器控制第一电机和第二电机两者向相反方向旋转。Preferably, the winding direction of the first right hoisting wire rope wound on the first tilting drum and the second right hoisting wire rope wound on the second tilting drum are the same; The winding direction of the first left hoisting wire rope on the drum and the second left hoisting wire rope wound on the second tilting drum are the same; when the operator needs to grab the container, the height difference between the left and right of the spreader assembly needs to be adjusted When; the controller controls the first motor and the second motor to rotate forward or reverse at the same time; when the operator needs to adjust the rotation of the spreader assembly; the controller controls the first motor and the second motor to rotate in opposite directions.
优选地,绕缠在第一倾转卷筒上第一右侧起升钢丝绳和绕缠在第二倾转卷筒上第二右侧起升钢丝绳绕缠方向相反;绕缠在第一倾转卷筒上第一左侧起升钢丝绳和绕缠在第二倾转卷筒上第二左侧起升钢丝绳绕缠方向相反;当操作手需要抓取集装箱,需要调整吊具总成左右高度差时;控制器控制第一电机和第二电机两者向相反方向旋转;当操作手需要调整吊具总成旋转时,控制器控制第一电机和第二电机同时正转或反转。Preferably, the winding direction of the first right hoisting wire rope wound on the first tilting drum and the second right hoisting wire rope wound on the second tilting drum are opposite; The winding direction of the first left hoisting wire rope on the drum is opposite to that of the second left hoisting wire rope wound on the second tilting drum; when the operator needs to grab the container, the height difference between the left and right of the spreader assembly needs to be adjusted when the controller controls the first motor and the second motor to rotate in opposite directions; when the operator needs to adjust the rotation of the spreader assembly, the controller controls the first motor and the second motor to rotate forward or reverse at the same time.
本实用新型还提供一种起重机,包括:如权利要求1至9任意一项所述的倾转驱动机构、横梁、大车、小车,机架安装在小车上,小车在横梁的轨道上行走,大车驱动整机行走。The utility model also provides a crane, comprising: the tilting drive mechanism described in any one of claims 1 to 9, a beam, a cart, and a trolley, the frame is mounted on the trolley, and the trolley walks on the track of the beam, The cart drives the whole machine to walk.
本实用新型提供的倾转驱动机构和起重机有益效果在于:The beneficial effects of the tilting drive mechanism and the crane provided by the utility model are:
其一,结构简单、调节吊具总成倾转角度大。其二、在第一倾转卷筒和第二倾转卷筒分别设置传感器用于检测旋转角度,通过计算精确反馈控制第一电机和第二电机旋转角度,从而实现精确调节吊具总成倾转角度的目的。其三,采用本实用新型倾转驱动机构,还可以控制吊具总成在一定范围内旋转实现与集装箱对箱问题。First, the structure is simple, and the tilting angle of the adjustable spreader assembly is large. Second, sensors are installed on the first tilting drum and the second tilting drum to detect the rotation angle, and the rotation angle of the first motor and the second motor is controlled through calculation and accurate feedback, so as to realize the precise adjustment of the tilting of the spreader assembly. purpose of turning angle. Third, adopting the tilting drive mechanism of the utility model can also control the rotation of the spreader assembly within a certain range to realize the alignment problem with the container.
附图说明 Description of drawings
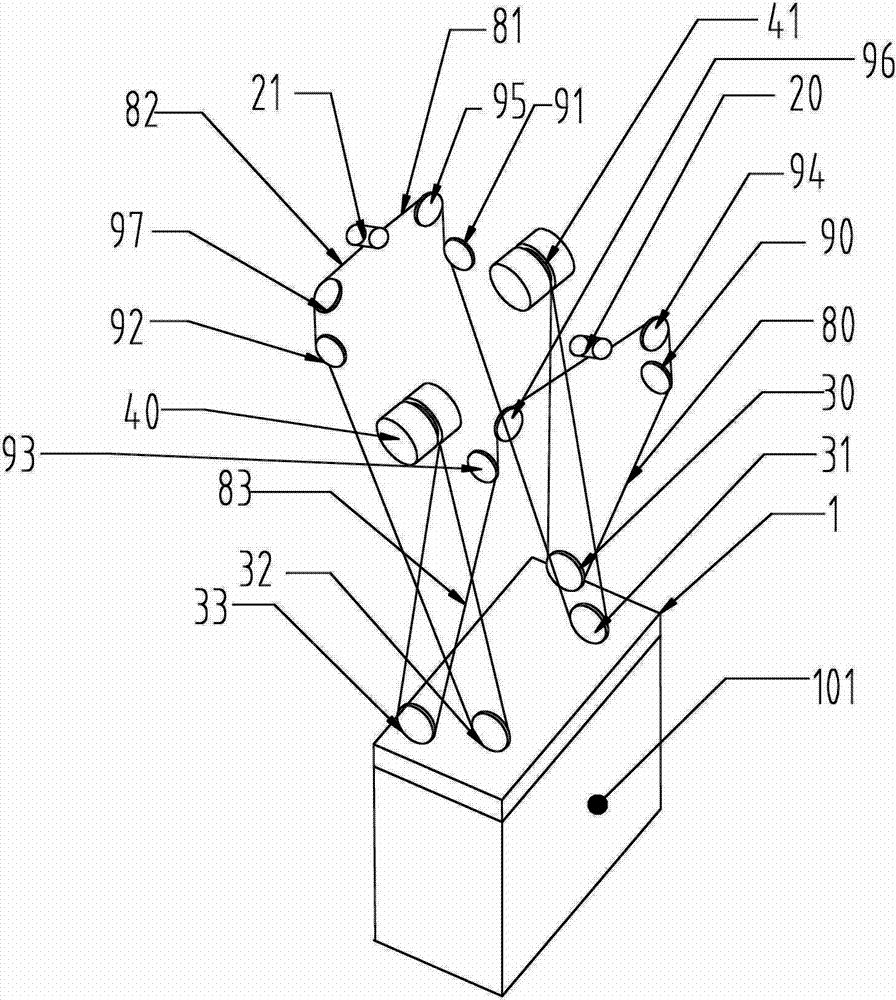
图1示出了本实用新型的倾转驱动机构主视图;Fig. 1 shows the front view of the tilting drive mechanism of the present utility model;
图2示出了图1的俯视图;Figure 2 shows a top view of Figure 1;
图3示出了图1的左侧视图;Fig. 3 shows the left side view of Fig. 1;
图4示出了本实用新型的倾转驱动机构钢丝绳绕缠示意图;Fig. 4 shows a schematic diagram of the wire rope winding of the tilting drive mechanism of the present invention;
图5示出了图1的倾转卷筒示意图。FIG. 5 shows a schematic diagram of the tilting reel of FIG. 1 .
具体实施方式 Detailed ways
下面结合附图说明根据本实用新型的具体实施方式。需要说明的是,在不冲突的情况下,本申请的实施例及实施例中的特征可以相互组合。The specific implementation manners according to the present utility model are described below in conjunction with the accompanying drawings. It should be noted that, in the case of no conflict, the embodiments of the present application and the features in the embodiments can be combined with each other.
在下面的描述中阐述了很多具体细节以便于充分理解本实用新型,但是,本实用新型还可以采用其他不同于在此描述的其他方式来实施,因此,本实用新型的保护范围并不受下面公开具体实施例的限制。In the following description, a lot of specific details have been set forth in order to fully understand the utility model, but the utility model can also be implemented in other ways different from those described here, therefore, the protection scope of the utility model is not limited by the following Limitations of specific embodiments are disclosed.
如图1、图2、图3所示,倾转驱动机构包括:机架5、吊具总成1(如图4所示)、机架5与小车6连接,小车驱动机架5在横梁的轨道100上移动。吊具总成1包括吊具上架11和吊具下架10组成,吊具下架10用于抓取集装箱101(如图4所示)货物,也可以设计抓取其它货物的吊具下架。吊具上架11与吊具下架10通过锁销可拆卸连接。吊具总成1也可以做成总体结构,或者其它类型。As shown in Figure 1, Figure 2, and Figure 3, the tilting drive mechanism includes:
安装于机架5上的左侧起升卷筒40、右侧起升卷筒41。左侧起升卷筒40和右侧起升卷筒41旋转轴线基本重合,通过电机减速后驱动左侧起升卷筒40和右侧起升卷筒41旋转,吊运集装箱货物。以左侧起升卷筒40和右侧起升卷筒41旋转轴线为对称面,设置有第一倾转卷筒21和第二倾转卷筒20,第一倾转卷筒21和第二倾转卷筒20安装在机架5上。第一倾转卷筒21和第二倾转卷筒20旋转轴线重合且与左侧起升卷筒40和右侧起升卷筒41旋转轴线彼此垂直,同时也可以不相互垂直,采用其它方式结构。The left lifting reel 40 and the right lifting reel 41 installed on the
在吊具上架11上两侧设置有第一左侧滑轮32、第二左侧滑轮33、第一右侧滑轮31、第二右侧滑轮30。如图3所示,第一左侧滑轮32和第一右侧滑轮31旋转轴线重合。第二左侧滑轮33和第二右侧滑轮30旋转轴线重合。具两者以吊具上架11的纵向中心平面对称设置。如图1所示,第一左侧滑轮32、第一右侧滑轮31、第二左侧滑轮33、第二右侧滑轮30均不在同一个旋转平面内。同时,也可以采用其它方式布置动滑轮。A first
还包括四根起升钢丝绳,第一左侧起升钢丝绳82、第二左侧起升钢丝绳83、第一右侧起升钢丝绳81、第二右侧起升钢丝绳80。It also includes four lifting wire ropes, the first left lifting wire rope 82, the second left lifting wire rope 83, the first right lifting wire rope 81, and the second right lifting wire rope 80.
在机架5上还设置8个导向滑轮,8个导向滑轮对称布置。每根起升钢丝绳配置有两个导向滑轮。8 guide pulleys are also arranged on the
如图4所示,第一左侧起升钢丝绳82一端固定在第一倾转卷筒21上后,依次绕缠在第一倾转卷筒21、导向滑轮97、导向滑轮92、第一左侧滑轮32、左侧起升卷筒40,然后另一端固定在左侧起升卷筒40上。As shown in Figure 4, after one end of the first left lifting wire rope 82 is fixed on the
第二左侧起升钢丝绳83一端固定在第二倾转卷筒20上后,依次绕缠在第二倾转卷筒20、导向滑轮96、导向滑轮93、第二左侧滑轮33、左侧起升卷筒40,然后另一端固定在左侧起升卷筒40。After one end of the second left lifting wire rope 83 is fixed on the second tilting
第一右侧起升钢丝绳81一端固定在第一倾转卷筒21上后,依次绕缠在第一倾转卷筒21、导向滑轮95、导向滑轮91、第一右侧滑轮31、右侧起升卷筒41,然后另一端固定在右侧起升卷筒41上。After one end of the first right lifting wire rope 81 is fixed on the
第二右侧起升钢丝绳80一端固定在第二倾转卷筒20上后,依次绕缠在第二倾转卷筒20、导向滑轮94、导向滑轮90、第二右侧滑轮31、右侧起升卷筒41、然后另一端固定在右侧起升卷筒41上。After one end of the second right lifting wire rope 80 is fixed on the second tilting
第一左侧起升钢丝绳82和第一右侧起升钢丝绳81绕缠在第一倾转卷筒21的绕缠方向相反,使得第一左侧起升钢丝绳82和第一右侧起升钢丝绳81出绳方向相反。不管第一倾转卷筒21是正转或反转,第一左侧起升钢丝绳82和第第一右侧起升钢丝绳81出绳方向相反,一个被第一倾转卷筒21卷起收绳,一个被第一倾转卷筒21放绳。从而实现左右侧收放绳自如,实现吊具上架11倾转驱动。The winding directions of the first left hoisting wire rope 82 and the first right hoisting wire rope 81 around the first tilting
同理,第二左侧起升钢丝绳83和第二右侧起升钢丝绳80绕缠在第二倾转卷筒20的绕缠方向相反,使得第二左侧起升钢丝绳83和第二右侧起升钢丝绳80出绳方向相反。Similarly, the winding directions of the second left hoisting wire rope 83 and the second right hoisting wire rope 80 on the second tilting
第一左侧起升钢丝绳82和第二左侧起升钢丝绳83绕缠在左侧起升卷筒40方向相同,当左侧起升卷筒40正转或反转,第一左侧起升钢丝绳82和第二左侧起升钢丝绳83同时收绳或放绳。The first left side hoisting wire rope 82 and the second left side hoisting wire rope 83 are wound around the left side hoisting drum 40 in the same direction. The wire rope 82 and the second left side hoisting wire rope 83 take in or release the rope simultaneously.
同理,第一右侧起升钢丝绳81和第二右侧起升钢丝绳80绕缠在右侧起升卷筒41方向相同。Similarly, the first right hoisting wire rope 81 and the second right hoisting wire rope 80 wind around the right hoisting drum 41 in the same direction.
第一左侧起升钢丝绳82、第二左侧起升钢丝绳83、第一右侧起升钢丝绳81、第二右侧起升钢丝绳80分别绕缠第一左侧滑轮32、第二左侧滑轮33、第一右侧滑轮31、第二右侧滑轮31角度相等,使得倾转驱动机构平衡。但是也可以不相等。The first left side hoisting wire rope 82, the second left side hoisting wire rope 83, the first right side hoisting wire rope 81, and the second right side hoisting wire rope 80 are respectively wound around the first
如图5和图3所示,第一倾转卷筒21由第一电机105通过减速机驱动旋转,在第一倾转卷筒21旋转轴上安装有第一传感器106。第二倾转卷筒20由第二电机102通过减速机103驱动旋转,在第二倾转卷筒20旋转轴上安装有第二传感器104。两个减速机内设置制动器,对第一倾转卷筒21和第二倾转卷筒20实现制动,这样就保证了倾转驱动机构的可靠停止或启动。As shown in FIG. 5 and FIG. 3 , the first tilting
第一传感器106和第二传感器104为绝对值编码器。用于检测第一倾转卷筒21和第二倾转卷筒20旋转角度。从而检测第一倾转卷筒21和第二倾转卷筒20收放绳长度,吊具总成1的倾转角度,反馈控制第一电机105和第二电机102旋转。第一传感器106和第二传感器104也可以采用其它类型的转角传感器,如角度传感器、电磁传感器等类型,也可以不采用传感器反馈控制技术,采用电机直接控制,但是控制精度较低。The
倾转驱动机构工作过程如下:The working process of the tilting drive mechanism is as follows:
一、倾转驱动机构需要起吊集装箱货物时,首先需要通过吊具下架10抓取集装箱,左侧起升卷筒40和右侧起升卷筒41同时反转,下放吊具下架10,然后调整吊具总成1倾转角度。1. When the tilting drive mechanism needs to lift container goods, firstly, the container needs to be grabbed by the
如果绕缠在第一倾转卷筒21上第一右侧起升钢丝绳81和绕缠在第二倾转卷筒20上第二右侧起升钢丝绳80绕缠方向相同;绕缠在第一倾转卷筒21上第一左侧起升钢丝绳82和绕缠在第二倾转卷筒20上第二左侧起升钢丝绳83绕缠方向相同;If the hoisting wire rope 81 on the first right side is wound on the first tilting
当操作手需要抓取集装箱101,需要调整吊具总成1左右高度差时;控制器控制第一电机105和第二电机102同时正转;使得第一右侧起升钢丝绳81和第二右侧起升钢丝绳80收绳,吊具总成1右侧增高;第一左侧起升钢丝绳82和第二左侧起升钢丝绳83放绳,吊具总成1左侧下降;达到调整吊具总成1左右高度差的目的。如果控制器控制第一电机105和第二电机102同时反转,同理。When the operator needs to grab the container 101 and adjust the left and right height difference of the spreader assembly 1; the controller controls the
当操作手需要调整吊具总成1旋转时;控制器控制第一电机105和第二电机102两者向相反方向旋转。如果第一电机105正转、第二电机102反转。使得第一倾转卷筒21正转、第二倾转卷筒20反转;第一右侧起升钢丝绳81和第二左侧起升钢丝绳83放绳而降低;第二右侧起升钢丝绳80和第一左侧起升钢丝绳82收绳而增高。吊具总成1因为一条对角线上增高,另一条对角线上降低。吊具总成1在自重的作用下,旋转一定角度,达到调节吊具总成1倾转角度的目的。When the operator needs to adjust the rotation of the spreader assembly 1 , the controller controls the
二、如果绕缠在第一倾转卷筒21上第一右侧起升钢丝绳81和绕缠在第二倾转卷筒20上第二右侧起升钢丝绳80绕缠方向相反;绕缠在第一倾转卷筒21上第一左侧起升钢丝绳82和绕缠在第二倾转卷筒20上第二左侧起升钢丝绳83绕缠方向相反;Two, if the hoisting wire rope 81 on the first right side is wound on the first tilting
当操作手需要抓取集装箱101,需要调整吊具总成1左右高度差时;同理,控制器控制第一电机105和第二电机102两者向相反方向旋转;当操作手需要调整吊具总成1旋转时,控制器控制第一电机105和第二电机102同时正转或反转。When the operator needs to grab the container 101 and needs to adjust the left and right height difference of the spreader assembly 1; similarly, the controller controls the
吊具总成1对箱完成后,抓取集装箱101,左侧起升卷筒40和右侧起升卷筒41同时正转,吊起集装箱101货物。After one pair of boxes is completed in the spreader assembly, the container 101 is grabbed, and the left lifting reel 40 and the right lifting reel 41 rotate forward simultaneously to lift the container 101 goods.
该倾转驱动机构采用一个倾转卷筒也可以实现倾转驱动的目的。The purpose of tilting drive can also be realized by adopting a tilting reel in the tilting drive mechanism.
本实用新型还提供一种具有该倾转驱动机构的起重机,包括、大车、小车、横梁、机架5安装在小车6上,小车6在横梁的轨道100上行走,大车驱动整机行走。The utility model also provides a crane with the tilting drive mechanism, which includes a cart, a trolley, a beam, and a
以上所述仅为本实用新型的优选实施例而已,并不用于限制本实用新型,对于本领域的技术人员来说,本实用新型可以有各种更改和变化。凡在本实用新型的精神和原则之内,所作的任何修改、等同替换、改进等,均应包含在本实用新型的保护范围之内。The above descriptions are only preferred embodiments of the utility model, and are not intended to limit the utility model. For those skilled in the art, the utility model can have various modifications and changes. Any modification, equivalent replacement, improvement, etc. made within the spirit and principles of the present utility model shall be included in the protection scope of the present utility model.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201220449878 CN202829333U (en) | 2012-09-05 | 2012-09-05 | Tilt rotation driving mechanism and crane |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201220449878 CN202829333U (en) | 2012-09-05 | 2012-09-05 | Tilt rotation driving mechanism and crane |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN202829333U true CN202829333U (en) | 2013-03-27 |
Family
ID=47941090
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN 201220449878 Expired - Fee Related CN202829333U (en) | 2012-09-05 | 2012-09-05 | Tilt rotation driving mechanism and crane |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN202829333U (en) |
Cited By (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN108689303A (en) * | 2018-06-29 | 2018-10-23 | 上海云童机械有限公司 | Anti-swing system and anti-swing method for four-rope RTG hoisting steel wire rope brake |
| CN109179202A (en) * | 2018-11-23 | 2019-01-11 | 新乡市豫新起重机械有限公司 | A kind of high-precision winding type electromagnetism docking shelf crane |
| CN109795952A (en) * | 2019-02-20 | 2019-05-24 | 青岛海西重机有限责任公司 | A kind of cable wire for crane hoisting system |
| CN110668338A (en) * | 2019-10-30 | 2020-01-10 | 河南省黄河防爆起重机有限公司 | A kind of crane double hoisting device and wire rope winding method |
| WO2022111412A1 (en) * | 2020-11-30 | 2022-06-02 | 三一海洋重工有限公司 | Device for controlling tilt of lifting tool, and crane |
-
2012
- 2012-09-05 CN CN 201220449878 patent/CN202829333U/en not_active Expired - Fee Related
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN108689303A (en) * | 2018-06-29 | 2018-10-23 | 上海云童机械有限公司 | Anti-swing system and anti-swing method for four-rope RTG hoisting steel wire rope brake |
| CN108689303B (en) * | 2018-06-29 | 2023-10-27 | 上海云童机电设备有限公司 | Anti-shaking system and anti-shaking method for four-rope RTG lifting steel wire rope brake |
| CN109179202A (en) * | 2018-11-23 | 2019-01-11 | 新乡市豫新起重机械有限公司 | A kind of high-precision winding type electromagnetism docking shelf crane |
| CN109795952A (en) * | 2019-02-20 | 2019-05-24 | 青岛海西重机有限责任公司 | A kind of cable wire for crane hoisting system |
| CN110668338A (en) * | 2019-10-30 | 2020-01-10 | 河南省黄河防爆起重机有限公司 | A kind of crane double hoisting device and wire rope winding method |
| WO2022111412A1 (en) * | 2020-11-30 | 2022-06-02 | 三一海洋重工有限公司 | Device for controlling tilt of lifting tool, and crane |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN201942459U (en) | Container crane lifting mechanism and container crane | |
| CN102471042B (en) | mobile crane | |
| CN106741707B (en) | A kind of automatic stowage balance system for rig a ship | |
| CN110407107B (en) | Accurate allocation and transportation hoist of qxcomm technology | |
| CN103184805B (en) | Stereoscopic garage | |
| CN202848895U (en) | Crane hoisting mechanism | |
| CN106081924B (en) | A kind of lightweight Multifunctional container gantry crane and its assemble method | |
| WO2025139105A1 (en) | Hoisting position and posture adjustment system and hoisting apparatus | |
| JP2013500917A5 (en) | ||
| CN107867650A (en) | A kind of new cast aluminium slab ingot upright intelligent handling apparatus | |
| CN105692464B (en) | A kind of incorgruous mobile crane span structure type crane of double trolley | |
| CN114148880A (en) | An unmanned automatic steel coil handling crane | |
| CN102826448B (en) | Hoisting mechanism and gantry crane | |
| CN103058059B (en) | Synchronous control device for double flat-arm tower crane and its hoisting trolley | |
| EP2927177B1 (en) | Method and arrangement for controlling a crane | |
| CN209554663U (en) | An Anti-Swing Crane Hoisting Mechanism | |
| CN210133822U (en) | A lifting and transferring device | |
| CN208200188U (en) | A kind of unmanned overhead traveling crane applied to concrete prefabricated element stockyard | |
| CN103466453B (en) | Control the method and system that crane hoisting is servo-actuated relative to arm | |
| CN202766182U (en) | Electric hydraulic control rope blocking device | |
| CN111439676A (en) | A hoisting wire rope stable motion system for field bridges | |
| CN116101914B (en) | Crane with crane body | |
| CN209127952U (en) | Comprehensive container handler | |
| CN209038888U (en) | A kind of high-precision winding type electromagnetism docking shelf crane | |
| CN109179202B (en) | High-precision winch type electromagnetic docking goods shelf crane |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| ASS | Succession or assignment of patent right |
Owner name: SANY MARINE HEAVY INDUSTRIES CO., LTD. Free format text: FORMER OWNER: KM GROUP CO., LTD. Effective date: 20150608 |
|
| C41 | Transfer of patent application or patent right or utility model | ||
| COR | Change of bibliographic data |
Free format text: CORRECT: ADDRESS; FROM: 410100 CHANGSHA, HUNAN PROVINCE TO: 519050 ZHUHAI, GUANGDONG PROVINCE |
|
| TR01 | Transfer of patent right |
Effective date of registration: 20150608 Address after: 519050 Guangdong city of Zhuhai province Pingsha town Ping Road No. 336 East Building Room 310 Patentee after: 31 ocean heavy industry Co., Ltds Address before: 410100 Changsha economic and Technological Development Zone, Hunan City, the 31 industrial city Patentee before: KM Group Co., Ltd. |
|
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20130327 Termination date: 20150905 |
|
| EXPY | Termination of patent right or utility model |