CN202668546U - Small rescue robot - Google Patents
Small rescue robot Download PDFInfo
- Publication number
- CN202668546U CN202668546U CN2012202852553U CN201220285255U CN202668546U CN 202668546 U CN202668546 U CN 202668546U CN 2012202852553 U CN2012202852553 U CN 2012202852553U CN 201220285255 U CN201220285255 U CN 201220285255U CN 202668546 U CN202668546 U CN 202668546U
- Authority
- CN
- China
- Prior art keywords
- gear motor
- handgrip
- side plate
- worm gear
- gripper
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
- 210000000078 claw Anatomy 0.000 claims abstract description 16
- 239000000758 substrate Substances 0.000 claims description 11
- XAGFODPZIPBFFR-UHFFFAOYSA-N aluminium Chemical compound [Al] XAGFODPZIPBFFR-UHFFFAOYSA-N 0.000 claims description 9
- 229910052782 aluminium Inorganic materials 0.000 claims description 9
- 230000001360 synchronised effect Effects 0.000 claims description 3
- 230000008878 coupling Effects 0.000 claims 2
- 238000010168 coupling process Methods 0.000 claims 2
- 238000005859 coupling reaction Methods 0.000 claims 2
- 238000010586 diagram Methods 0.000 description 2
- 230000004888 barrier function Effects 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 238000000034 method Methods 0.000 description 1
- 230000009528 severe injury Effects 0.000 description 1
Images


Landscapes
- Emergency Lowering Means (AREA)
Abstract
本实用新型公开了一种小型救援机器人,包括控制系统、抓手、基板和位于基板两侧的侧板,侧板的外侧设置有行进驱动装置,特点是基板上设置有抓手转动驱动装置和破障装置,抓手转动驱动装置包括抓手安装板、第一蜗轮蜗杆电机和第二蜗轮蜗杆电机,第一蜗轮蜗杆电机固定安装在基板上,抓手安装板与第一蜗轮蜗杆电机的输出轴固定连接,第二蜗轮蜗杆电机固定安装在抓手安装板上,抓手包括固定爪和活动爪,固定爪固定安装在抓手安装板的端部,活动爪与第二蜗轮蜗杆电机的输出轴固定连接;优点是该机器人结构简单,而且功能较多,应用广泛,即可用于在工程救援时寻找失踪人员或贵重物品,又可充当探路先锋,降低救援的危险系数。
The utility model discloses a small-sized rescue robot, which comprises a control system, a gripper, a base plate and side plates located on both sides of the base plate. A driving device is arranged on the outer side of the side plate. The barrier-breaking device, the gripper rotation drive device includes a gripper mounting plate, a first worm gear motor and a second worm gear motor, the first worm gear motor is fixedly installed on the base plate, and the output of the gripper mounting plate and the first worm gear motor The shaft is fixedly connected, the second worm gear motor is fixedly installed on the gripper mounting plate, the gripper includes a fixed claw and a movable claw, the fixed claw is fixedly installed at the end of the gripper mounting plate, the output of the movable claw and the second worm gear motor The shaft is fixedly connected; the advantage is that the robot has a simple structure, more functions, and a wide range of applications. It can be used to find missing persons or valuables during engineering rescue, and can also act as a pathfinder pioneer to reduce the risk factor of rescue.
Description
技术领域 technical field
本实用新型涉及一种救援设备,尤其涉及一种小型救援机器人。 The utility model relates to a rescue device, in particular to a small rescue robot.
背景技术 Background technique
在世界各地,由于自然灾害、恐怖活动和各种突发事故等原因,灾难经常发生。在灾难救援中,救援人员需要尽快在倒塌的废墟中寻找幸存者。目前,在多数情况下还是靠救护人员进行一线营救,但是在破坏严重的灾难现场,常规大型救援机械很难在灾难第一时间展开救援,而且由于地形复杂和灾难破坏,救灾现场对救援人员的生命安全也造成了巨大的威胁。此时,机器人就可以为救援人员提供帮助。但是目前很多小型救援机器人其功能有限,应用范围较窄,无法在救灾现场充分发挥机器人的作用。 All over the world, disasters often occur due to natural disasters, terrorist activities and various unexpected accidents. In disaster relief, rescuers need to find survivors among the collapsed ruins as quickly as possible. At present, in most cases, it is still relying on rescue personnel to carry out first-line rescue. However, at the disaster scene with severe damage, it is difficult for conventional large-scale rescue machinery to carry out rescue at the first time of the disaster. Life safety also poses a huge threat. At this point, the robot can provide assistance to rescuers. However, at present, many small rescue robots have limited functions and a narrow range of applications, so they cannot fully play the role of robots at disaster relief sites.
发明内容 Contents of the invention
本实用新型所要解决的技术问题是提供一种功能多、应用范围广的小型救援机器人。 The technical problem to be solved by the utility model is to provide a small rescue robot with multiple functions and wide application range.
本实用新型解决上述技术问题所采用的技术方案为:一种小型救援机器人,包括控制系统、抓手、基板和位于所述的基板两侧的侧板,所述的侧板的外侧设置有行进驱动装置,所述的基板上设置有抓手转动驱动装置和破障装置,所述的抓手转动驱动装置包括抓手安装板、用于驱动所述的抓手安装板上下转动的第一蜗轮蜗杆电机和用于驱动所述的抓手开合的第二蜗轮蜗杆电机,所述的第一蜗轮蜗杆电机固定安装在所述的基板上,所述的抓手安装板与所述的第一蜗轮蜗杆电机的输出轴固定连接,所述的第二蜗轮蜗杆电机固定安装在所述的抓手安装板上,所述的抓手包括固定爪和活动爪,所述的固定爪固定安装在所述的抓手安装板的端部,所述的活动爪与所述的第二蜗轮蜗杆电机的输出轴固定连接,所述的基板上固定设置有位于所述的抓手安装板后侧的储物箱。 The technical solution adopted by the utility model to solve the above-mentioned technical problems is: a small rescue robot, including a control system, a gripper, a base plate and side plates located on both sides of the base plate. Drive device, the base plate is provided with a gripper rotation drive device and a barrier-breaking device, the gripper rotation drive device includes a gripper mounting plate, a first worm wheel for driving the gripper mounting plate to rotate up and down A worm motor and a second worm gear motor for driving the opening and closing of the gripper, the first worm gear motor is fixedly installed on the base plate, and the gripper mounting plate is connected with the first The output shaft of the worm gear motor is fixedly connected, the second worm gear motor is fixedly installed on the gripper mounting plate, the gripper includes a fixed claw and a movable claw, and the fixed claw is fixedly installed on the The end of the gripper mounting plate, the movable claw is fixedly connected to the output shaft of the second worm gear motor, and the base plate is fixedly provided with a storage tank located on the rear side of the gripper mounting plate. box.
所述的破障装置包括第一驱动气缸、角铝架和顶杆,所述的角铝架固定安装在所述的基板上,所述的顶杆的上端和所述的第一驱动气缸的尾端分别轴接在所述的角铝架上,所述的顶杆的端部固定设置有顶板,所述的第一驱动气缸的前端与所述的顶杆相轴接。 The barrier breaking device includes a first drive cylinder, an angle aluminum frame and a push rod, the angle aluminum frame is fixedly installed on the base plate, the upper end of the push rod and the first drive cylinder The tail ends are respectively pivotally connected to the angle aluminum frame, the end of the ejector rod is fixedly provided with a top plate, and the front end of the first driving cylinder is axially connected to the ejector rod.
所述的行进驱动装置包括驱动电机、前轮和后轮,所述的前轮和后轮均为履带轮,所述的驱动电机固定安装在所述的侧板上,所述的后轮同轴固定安装在所述的驱动电机的驱动轴上,所述的前轮轴接在所述的侧板上,所述的前轮与所述的后轮之间设置有同步履带。 The traveling driving device includes a driving motor, a front wheel and a rear wheel, the front wheels and the rear wheels are track wheels, the driving motor is fixedly mounted on the side plate, and the rear wheel is the same as The shaft is fixedly installed on the drive shaft of the drive motor, the front wheel shaft is connected to the side plate, and a synchronous track is arranged between the front wheel and the rear wheel.
所述的两块侧板之间设置有伸缩机构。 A telescopic mechanism is arranged between the two side plates.
所述的伸缩机构包括第二驱动气缸,所述的第二驱动气缸的尾端固定连接在位于所述的基板一侧的侧板上,所述的第二驱动气缸的驱动杆与位于所述的基板另一侧的侧板固定连接,其中一侧的侧板上固定设置有第一滑轨,另一侧的侧板上固定设置有第二滑轨,所述的第一滑轨与所述的第二滑轨滑动配合,所述的基板固定安装在所述的第一滑轨上。 The telescoping mechanism includes a second driving cylinder, the tail end of the second driving cylinder is fixedly connected to the side plate on one side of the base plate, and the driving rod of the second driving cylinder is connected to the side plate on the side of the base plate. The side plate on the other side of the substrate is fixedly connected, wherein the side plate on one side is fixedly provided with a first slide rail, and the side plate on the other side is fixedly provided with a second slide rail, and the first slide rail is connected to the The second slide rail is slidingly fitted, and the base plate is fixedly installed on the first slide rail. the
与现有技术相比,本实用新型的优点是由于基板上设置有抓手转动驱动装置和破障装置,且基板上固定设置有储物箱,在该机器人实施救援时,可通过破障装置顶开路障,保证机器人的顺利行进,同时还可通过抓手转动驱动装置抓取目标并放入储物箱;此外,由于两块侧板之间设置有伸缩机构,使该机器人还可通过伸缩机构调解自身的宽度,顺利通过对机器人宽度有限制的地面,其结构简单,而且功能较多,应用广泛,即可用于在工程救援时寻找失踪人员或贵重物品,又可充当探路先锋,降低救援的危险系数。 Compared with the prior art, the utility model has the advantage that since the base plate is provided with a gripper rotation drive device and a barrier-breaking device, and a storage box is fixedly arranged on the base plate, when the robot performs rescue, it can pass through the barrier-breaking device Open the roadblock to ensure the smooth progress of the robot. At the same time, the target can be grabbed by the gripper rotation drive device and put into the storage box; in addition, since the telescopic mechanism is set between the two side plates, the robot can The mechanism adjusts its own width and passes through the ground with limited width. It has a simple structure, more functions, and a wide range of applications. It can be used to find missing persons or valuables during engineering rescue, and can also act as a pathfinder pioneer to reduce Rescue risk factor.
附图说明 Description of drawings
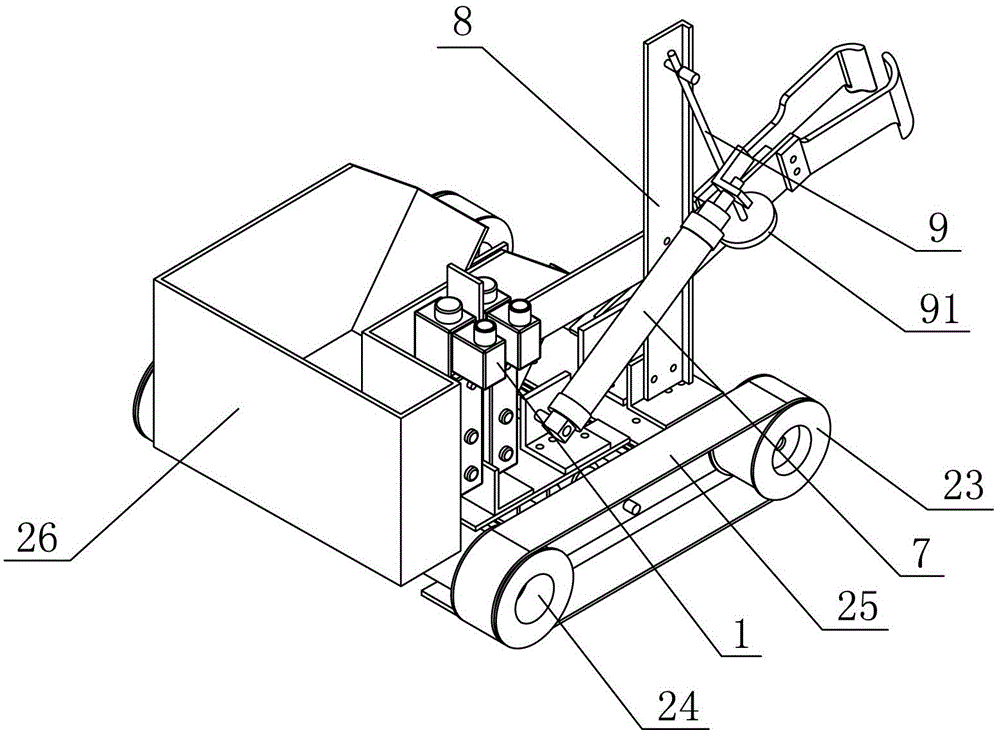
图1为本实用新型的立体结构示意图; Fig. 1 is the three-dimensional structure schematic diagram of the present utility model;
图2为本实用新型去掉储物箱后的立体结构示意图; Fig. 2 is the three-dimensional structural schematic diagram of the utility model after removing the storage box;
图3为图2的俯视图。 FIG. 3 is a top view of FIG. 2 .
具体实施方式 Detailed ways
以下结合附图实施例对本实用新型作进一步详细描述。 The utility model is described in further detail below in conjunction with the accompanying drawings.
如图所示,一种小型救援机器人,包括控制系统1、抓手、基板2和位于基板2两侧的侧板21,侧板21的外侧分别设置有行进驱动装置,行进驱动装置包括驱动电机22、前轮23和后轮24,前轮23和后轮24均为履带轮,驱动电机22固定安装在侧板21上,后轮24同轴固定安装在驱动电机22的驱动轴上,前轮23轴接在侧板21上,前轮23与后轮24之间设置有同步履带25,两块侧板21之间设置有伸缩机构,伸缩机构包括第二驱动气缸3,第二驱动气缸3的尾端固定连接在位于基板2一侧的侧板21上,第二驱动气缸3的驱动杆与位于基板2另一侧的侧板21固定连接,其中一侧的侧板21上固定设置有第一滑轨31,另一侧的侧板21上固定设置有第二滑轨32,第一滑轨31与第二滑轨32滑动配合,基板2固定安装在第一滑轨31上,基板2上设置有抓手转动驱动装置和破障装置,抓手转动驱动装置包括抓手安装板4、用于驱动抓手安装板4上下转动的第一蜗轮蜗杆电机5和用于驱动抓手开合的第二蜗轮蜗杆电机6,第一蜗轮蜗杆电机5固定安装在基板2上,抓手安装板4与第一蜗轮蜗杆电机5的输出轴固定连接,第二蜗轮蜗杆电机6固定安装在抓手安装板4上,抓手包括固定爪41和活动爪42,固定爪41固定安装在抓手安装板4的端部,活动爪42与第二蜗轮蜗杆电机6的输出轴固定连接,基板2上固定设置有位于抓手安装板4后侧的储物箱26,破障装置包括第一驱动气缸7、角铝架8和顶杆9,角铝架8固定安装在基板2上,顶杆9的上端和第一驱动气缸7的尾端分别轴接在角铝架8上,顶杆9的端部固定设置有顶板91,第一驱动气缸7的前端与顶杆9相轴接,驱动电机22、第一驱动气缸7、第二驱动气缸3、第一蜗轮蜗杆电机5和第二蜗轮蜗杆电机6分别与控制系统1电连接。
As shown in the figure, a small rescue robot includes a control system 1, a gripper, a
Claims (5)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN2012202852553U CN202668546U (en) | 2012-06-14 | 2012-06-14 | Small rescue robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN2012202852553U CN202668546U (en) | 2012-06-14 | 2012-06-14 | Small rescue robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN202668546U true CN202668546U (en) | 2013-01-16 |
Family
ID=47489479
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN2012202852553U Expired - Fee Related CN202668546U (en) | 2012-06-14 | 2012-06-14 | Small rescue robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN202668546U (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN106493741A (en) * | 2016-11-28 | 2017-03-15 | 广西乐美趣智能科技有限公司 | A kind of hotel service Multifunctional intelligent robot |
| CN107186737A (en) * | 2017-05-21 | 2017-09-22 | 吴静 | It is a kind of to be used to clear up the intelligent robot and its method of work of sending vehicle pendant thing back to |
-
2012
- 2012-06-14 CN CN2012202852553U patent/CN202668546U/en not_active Expired - Fee Related
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN106493741A (en) * | 2016-11-28 | 2017-03-15 | 广西乐美趣智能科技有限公司 | A kind of hotel service Multifunctional intelligent robot |
| CN107186737A (en) * | 2017-05-21 | 2017-09-22 | 吴静 | It is a kind of to be used to clear up the intelligent robot and its method of work of sending vehicle pendant thing back to |
| CN107186737B (en) * | 2017-05-21 | 2019-11-22 | 江苏禹高物联科技有限公司 | It is a kind of for clear up send back to vehicle pendant object intelligent robot and its working method |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102849132B (en) | Wheel-track compound deformation track robot | |
| CN102514640B (en) | A Transformable Rescue Robot | |
| CN104875811B (en) | A kind of compound obstacle crossing device of wheel leg assist type | |
| CN206552138U (en) | Based on wheel-track combined robot ambulation chassis | |
| CN105313997A (en) | Dual mode mobile robot | |
| CN102814810B (en) | Rescue device | |
| CN103317987A (en) | Off-road vehicle with wheels capable of being lifted and landed freely | |
| CN101403258A (en) | Vehicle conveying device | |
| WO2017067107A1 (en) | Automatic raising/lowering wheel mechanism, and intelligent luggage and method of using same | |
| CN202569244U (en) | Disaster resistant rescue robot with variable wheel tread and adjustable center height | |
| CN103290801A (en) | Road snow sweeping machine with V-shaped rolling brush of tricycle | |
| CN103754280B (en) | Overturn-preventing surrounding crawler-type mobile mechanism | |
| CN104526678A (en) | Explosive-handling robot | |
| CN102814811B (en) | Rescue robot | |
| CN103818488A (en) | Triangular crawler wheel translation mechanism for rescue robot | |
| CN202777513U (en) | Rescue robot | |
| CN104709373B (en) | Movable type gap opening robot | |
| CN108016705A (en) | A kind of conveying arrangement for fixing oil production tubing | |
| CN103786159A (en) | Robot | |
| CN104260795A (en) | Chassis capable of freely switching between crawler type walking mode and wheel type walking mode | |
| CN203600233U (en) | Compact type robot capable of operating within wide range | |
| CN202358209U (en) | Rescue robot | |
| CN104442191A (en) | Obstacle surmounting wheel with double eccentric circles and variable eccentric distances | |
| CN204278929U (en) | Two eccentric Variable Eccentricity Stump-jump wheel | |
| CN204271534U (en) | A kind of inspection robot and folding wheel thereof are grabbed |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20130116 Termination date: 20150614 |
|
| EXPY | Termination of patent right or utility model |