CN202527388U - Charged sweeping robot - Google Patents
Charged sweeping robot Download PDFInfo
- Publication number
- CN202527388U CN202527388U CN2012201360316U CN201220136031U CN202527388U CN 202527388 U CN202527388 U CN 202527388U CN 2012201360316 U CN2012201360316 U CN 2012201360316U CN 201220136031 U CN201220136031 U CN 201220136031U CN 202527388 U CN202527388 U CN 202527388U
- Authority
- CN
- China
- Prior art keywords
- cleaning robot
- control module
- mechanical arm
- mobile trolley
- platform
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Lifetime
Links
Images



Classifications
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02E—REDUCTION OF GREENHOUSE GAS [GHG] EMISSIONS, RELATED TO ENERGY GENERATION, TRANSMISSION OR DISTRIBUTION
- Y02E10/00—Energy generation through renewable energy sources
- Y02E10/50—Photovoltaic [PV] energy
Landscapes
- Electric Suction Cleaners (AREA)
Abstract
本实用新型公开了一种带电清扫机器人,包含电路控制装置,移动小车、依次连接设置在该移动小车上的升降台、横移台、伸缩滑台,以及与伸缩滑台相连的机械臂。移动小车包含车厢,设置在车厢两侧若干平衡支腿以及设置在车厢顶部的回转支撑。升降台包含固定支架,设置在固定支架上的升降机构,以及分别设置在固定支架底端和顶端的驱动机构;固定支架设置在回转支撑上。该机器人能按照被清扫物(各种高压设备)的外形实现机械臂的升降、伸缩和横移等功能,机械臂端部的毛刷需实现旋转和俯仰摆动,从而实现该清扫机器对高压设备进行全方位自动的清扫工作。
The utility model discloses an electrified cleaning robot, which comprises a circuit control device, a mobile trolley, a lifting platform arranged on the mobile trolley, a traverse platform, a telescopic sliding platform, and a mechanical arm connected with the telescopic sliding platform in sequence. The mobile trolley includes a compartment, a number of balance legs arranged on both sides of the compartment and a slewing support arranged on the top of the compartment. The lifting table includes a fixed support, a lifting mechanism arranged on the fixed support, and a driving mechanism respectively arranged at the bottom and the top of the fixed support; the fixed support is arranged on the slewing support. The robot can realize the lifting, telescopic and lateral movement of the mechanical arm according to the shape of the object to be cleaned (various high-voltage equipment). Carry out all-round automatic cleaning work.
Description
技术领域 technical field
本实用新型涉及一种机器人,具体涉及一种带电清扫机器人。 The utility model relates to a robot, in particular to a live cleaning robot. the
背景技术 Background technique
目前,在我国已经建成并投入使用的高压变电站有十几万座,每年安排高压设备的清扫就需花费巨大的人力、物力、财力和时间。高压设备清扫主要依靠“逢停必扫”的措施。停电倒闸操作、安全措施实施和停运时间的限制,给高压设备清扫质量以及系统的安全运行带来较多的问题。设备污闪隐患越来越严重的问题严重威胁着电力系统的安全运行,带电清扫作业势在必行。 At present, there are more than 100,000 high-voltage substations that have been built and put into use in my country. It takes a huge amount of manpower, material resources, financial resources and time to arrange the cleaning of high-voltage equipment every year. The cleaning of high-pressure equipment mainly relies on the measure of "every stop must be cleaned". Power failure switching operation, implementation of safety measures and limitation of outage time have brought many problems to the cleaning quality of high-voltage equipment and the safe operation of the system. The more and more serious hidden dangers of equipment pollution flashover seriously threaten the safe operation of the power system, and live cleaning operations are imperative. the
但是对于例如高压开关仓隔离开关、穿墙套管、绝缘子等的高压设备,如果仍然停留在人工清扫阶段(至少1人清扫1人监护),不仅操作劳动强度高、效率低,而且还存在不少安全事故隐患,在高压电环境下人员安全性难以得到保障。 However, for high-voltage equipment such as isolating switches in high-voltage switch compartments, wall bushings, insulators, etc., if they still stay in the manual cleaning stage (at least one person cleans and one person monitors), not only the operation is labor-intensive and inefficient, but also there are problems. There are few hidden dangers of safety accidents, and it is difficult to guarantee the safety of personnel in a high-voltage environment. the
因此,需要提出一种带电清扫机器人,其是应用在高压电环境下的清扫机器。 Therefore, it is necessary to propose a live cleaning robot, which is a cleaning machine applied in a high voltage environment. the
实用新型内容 Utility model content
本实用新型提供了一种带电清扫机器人,该机器人能按照被清扫物(各种高压设备)的外形实现机械臂的升降、伸缩和横移等功能,机械臂端部的毛刷需实现旋转和俯仰摆动,从而实现该清扫机器对高压设备进行全方位自动的清扫工作。 The utility model provides an electrified cleaning robot, which can realize functions such as lifting, telescopic and lateral movement of the mechanical arm according to the shape of the object to be cleaned (various high-voltage equipment), and the brush at the end of the mechanical arm needs to realize rotation and Pitch and swing, so that the cleaning machine can automatically clean the high-voltage equipment in all directions. the
为了达到上述目的,本实用新型通过以下技术方案实现: In order to achieve the above object, the utility model is realized through the following technical solutions:
一种带电清扫机器人,包含电路控制装置,其特点是,还包含:移动小车、依次连接设置在该移动小车上的升降台、横移台、伸缩滑台,以及与伸缩滑台相连的机械臂。 A live cleaning robot, including a circuit control device, is characterized in that it also includes: a mobile trolley, a lifting platform sequentially connected to the mobile trolley, a traverse platform, a telescopic sliding platform, and a mechanical arm connected to the telescopic sliding platform .
所述的移动小车包含车厢,设置在车厢两侧若干平衡支腿以及设置在车厢顶部的回转支撑。 The mobile trolley includes a carriage, a number of balance legs arranged on both sides of the carriage and a slewing support arranged on the top of the carriage. the
所述的升降台包含固定支架,设置在所述固定支架上的升降机构,以及分别设置在固定支架底端和顶端的驱动机构;所述的固定支架设置在回转支撑上。 The lifting table includes a fixed support, a lifting mechanism arranged on the fixed support, and a driving mechanism respectively arranged at the bottom and the top of the fixed support; the fixed support is arranged on the slewing support. the
所述的横移台包含: The traverse table includes:
滑台,所述的滑台设置在固定支架上; a slide table, the slide table is arranged on a fixed support;
设置在所述滑台上相对两侧的主滑动组件和辅助滑动组件; a main slide assembly and an auxiliary slide assembly arranged on opposite sides of the slide table;
其中,所述主滑动组件和辅助滑动组件承载带电清扫机器人的机械臂,带动所述机械臂在水平范围内进行横移运动。 Wherein, the main sliding assembly and the auxiliary sliding assembly carry the mechanical arm of the charged cleaning robot, and drive the mechanical arm to move laterally within a horizontal range.
所述的机械臂包含依次连接设置的支撑臂、手腕机构及毛刷;所述的支撑臂并与伸缩滑台相连。 The mechanical arm includes a support arm, a wrist mechanism and a brush arranged sequentially; the support arm is also connected with a telescopic slide table. the
所述的电路控制装置包含: The circuit control device includes:
电池控制模块、电路连接该电池控制模块的驱动器模块、电路连接该电池控制模块和驱动器模块的运动控制模块,还包含电路连接该电池控制模块的电池,以及电路连接该运动控制模块的天线。 A battery control module, a driver module circuit connected to the battery control module, a motion control module circuit connected to the battery control module and the driver module, a battery circuit connected to the battery control module, and an antenna circuit connected to the motion control module.
本实用新型一种带电清扫机器人与现有技术相比具有以下优点: Compared with the prior art, a live cleaning robot of the utility model has the following advantages:
该机器人能按照被清扫物(各种高压设备)的外形实现机械臂的升降、伸缩和横移等功能,机械臂端部的毛刷需实现旋转和俯仰摆动,从而实现该清扫机器对高压设备进行全方位自动的清扫工作。 The robot can realize the lifting, telescopic and lateral movement of the mechanical arm according to the shape of the object to be cleaned (various high-voltage equipment). Carry out all-round automatic cleaning work.
附图说明 Description of drawings
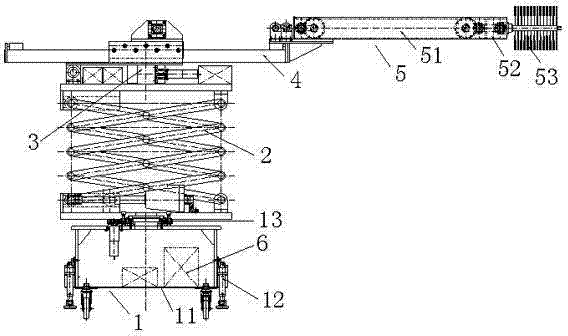
图1为本实用新型一种带电清扫机器人的结构示意图; Fig. 1 is the structural representation of a kind of charged cleaning robot of the present utility model;
图2为本实用新型一种带电清扫机器人的工作时的结构示意图; Fig. 2 is a schematic structural view of a live cleaning robot of the present invention when it is working;
图3为本实用新型一种带电清扫机器人的升降台的结构示意图; Fig. 3 is a structural schematic diagram of a lifting platform of a live cleaning robot of the present invention;
图4为本实用新型一种带电清扫机器人的横移台的结构示意图; Fig. 4 is a structural schematic diagram of a traversing platform of a charged cleaning robot of the present invention;
图5为本实用新型一种带电清扫机器人的电路控制装置的电路原理图。 Fig. 5 is a schematic circuit diagram of a circuit control device of a live cleaning robot of the present invention.
具体实施方式 Detailed ways
以下结合附图,通过详细说明一个较佳的具体实施例,对本实用新型做进一步阐述。 The utility model will be further elaborated below by describing a preferred specific embodiment in detail in conjunction with the accompanying drawings. the
如图1所示,一种带电清扫机器人,包含电路控制装置6、移动小车1、依次连接设置在该移动小车1上的升降台2、横移台3、伸缩滑台4,以及与伸缩滑台4相连的机械臂5。所述的机械臂5包含依次连接设置的支撑臂51、手腕机构52及毛刷53;所述的支撑臂52并与伸缩滑台4相连。所述的移动小车1包含车厢11,设置在车厢11两侧若干平衡支腿12以及设置在车厢11顶部的回转支撑13。
As shown in Figure 1, a kind of electrified cleaning robot comprises
如图3所示,所述的升降台2包含固定支架21,设置在所述固定支架21上的升降机构22,以及分别设置在固定支架21底端和顶端的驱动机构23;所述的固定支架21设置在回转支撑13上。
As shown in Figure 3, described
如图4所示,所述的横移台3包含:滑台31,所述的滑台31设置在固定支架21上;设置在所述滑台31上相对两侧的主滑动组件32和辅助滑动组件33;其中,所述主滑动组件32和辅助滑动组件33承载带电清扫机器人的机械臂5,带动所述机械臂5在水平范围内进行横移运动。
As shown in Figure 4, the described
如图5所示,所述的电路控制装置包含:电池控制模块604、电路连接该电池控制模块604的驱动器模块602、电路连接该电池控制模块604和驱动器模块602的运动控制模块603,还包含电路连接该电池控制模块604的电池601,以及电路连接该运动控制模块603的天线605。
As shown in Figure 5, the described circuit control device includes: a
如图2所示,本实用新型现场应用时,推动移动小车到合适的高压设备附近,通过电路控制装置升降台2、横移台3及伸缩滑台4升降及移动,使手腕机构52的毛刷53,靠近到需要清扫的高压设备合适位置,最后再通过机械臂端部的毛刷53需实现旋转和俯仰摆动,从而实现该清扫机器对高压设备进行全方位自动的清扫工作。
As shown in Figure 2, when the utility model is applied in the field, push the mobile trolley to the vicinity of suitable high-voltage equipment, lift and move the lifting table 2, the traverse table 3 and the telescopic sliding table 4 through the circuit control device, so that the hair of the
尽管本实用新型的内容已经通过上述优选实施例作了详细介绍,但应当认识到上述的描述不应被认为是对本实用新型的限制。在本领域技术人员阅读了上述内容后,对于本实用新型的多种修改和替代都将是显而易见的。因此,本实用新型的保护范围应由所附的权利要求来限定。 Although the content of the present invention has been described in detail through the above preferred embodiments, it should be recognized that the above description should not be considered as a limitation of the present invention. Various modifications and substitutions of the present utility model will be obvious to those skilled in the art after reading the above content. Therefore, the protection scope of the present utility model should be defined by the appended claims. the
Claims (6)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN2012201360316U CN202527388U (en) | 2012-03-31 | 2012-03-31 | Charged sweeping robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN2012201360316U CN202527388U (en) | 2012-03-31 | 2012-03-31 | Charged sweeping robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN202527388U true CN202527388U (en) | 2012-11-14 |
Family
ID=47128594
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN2012201360316U Expired - Lifetime CN202527388U (en) | 2012-03-31 | 2012-03-31 | Charged sweeping robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN202527388U (en) |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102698970A (en) * | 2012-03-31 | 2012-10-03 | 上海市电力公司 | A live cleaning robot |
| CN103845001A (en) * | 2012-12-05 | 2014-06-11 | 科沃斯机器人科技(苏州)有限公司 | Lifting swinging device, automatic dust discharging system with same, monitoring robot with same and dust absorbing device with same |
| CN104242120A (en) * | 2014-09-10 | 2014-12-24 | 国家电网公司 | Transformer substation disconnecting link electrified automatic washing device |
| CN104909269A (en) * | 2015-06-20 | 2015-09-16 | 苏州蓝王机床工具科技有限公司 | Hoisting device of crane |
-
2012
- 2012-03-31 CN CN2012201360316U patent/CN202527388U/en not_active Expired - Lifetime
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102698970A (en) * | 2012-03-31 | 2012-10-03 | 上海市电力公司 | A live cleaning robot |
| CN103845001A (en) * | 2012-12-05 | 2014-06-11 | 科沃斯机器人科技(苏州)有限公司 | Lifting swinging device, automatic dust discharging system with same, monitoring robot with same and dust absorbing device with same |
| CN103845001B (en) * | 2012-12-05 | 2017-12-22 | 科沃斯机器人股份有限公司 | Lifting and swinging device and its automatic ash discharge system, supervisory-controlled robot and suction apparatus for ash |
| CN104242120A (en) * | 2014-09-10 | 2014-12-24 | 国家电网公司 | Transformer substation disconnecting link electrified automatic washing device |
| CN104242120B (en) * | 2014-09-10 | 2016-01-20 | 国家电网公司 | The charged automatic flushing device of a kind of transformer station's disconnecting link |
| CN104909269A (en) * | 2015-06-20 | 2015-09-16 | 苏州蓝王机床工具科技有限公司 | Hoisting device of crane |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102698970A (en) | A live cleaning robot | |
| CN100413605C (en) | Two-stage lifting ultra-high voltage live cleaning robot | |
| CN201808061U (en) | Insulation system for high-voltage live-working robots | |
| CN209606580U (en) | A kind of state parameter on-Line Monitor Device of intelligent high-voltage vacuum circuit breaker | |
| CN202308915U (en) | Telescopic wire shielding cover for live working in distribution network | |
| CN103433242B (en) | Transformer station's dry ice cleaning vehicle | |
| CN102601782A (en) | High-voltage live working robot device | |
| CN107570452A (en) | A kind of robot of electrification in high voltage automatic cleaning insulator | |
| CN102615637A (en) | Master-slave control robot work platform for high-voltage live working | |
| CN110645155A (en) | Special detection, repair and crawling device for wind power generation tower operation | |
| CN201742012U (en) | Phase determination movable bracket for metal enclosed 10 kV high voltage switch cabinet | |
| CN205016893U (en) | High voltage isolator overhauls platform | |
| CN203026847U (en) | Intelligent detection robot for push rod peristaltic insulator chain | |
| CN103433244B (en) | Transformer station's dry ice cleaning vehicle | |
| CN202528198U (en) | Transverse moving table for mechanical arm of electrified cleaning robot | |
| CN203553678U (en) | Push rod used in electricity detection of switch cabinet | |
| CN202529783U (en) | Lifting platform of electrified sweeping robot | |
| CN202178487U (en) | Cleaning carbon brush for sliding contact wire | |
| CN115722479A (en) | A decontamination robot for insulator strings in DC converter stations | |
| CN202527439U (en) | Moving trolley for hot-line cleaning robot | |
| CN109683011A (en) | Electrical test aids | |
| CN203825047U (en) | Electricity detection platform | |
| CN204204695U (en) | High-pressure disconnecting switch motor structure assembly tool | |
| CN202720468U (en) | Controlling device for power transformation equipment high-voltage electriferous cleaning robot | |
| CN102706727B (en) | Simulated test device for construction elevator cable |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| ASS | Succession or assignment of patent right |
Owner name: STATE ELECTRIC NET CROP. Effective date: 20121105 |
|
| C41 | Transfer of patent application or patent right or utility model | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20121105 Address after: 200002 Nanjing East Road, Shanghai, No. 181, No. Patentee after: Shanghai Electric Power Corporation Patentee after: State Grid Corporation of China Address before: 200002 Nanjing East Road, Shanghai, No. 181, No. Patentee before: Shanghai Electric Power Corporation |
|
| CX01 | Expiry of patent term |
Granted publication date: 20121114 |
|
| CX01 | Expiry of patent term |