CN116297843A - Ultrasonic testing equipment - Google Patents
Ultrasonic testing equipment Download PDFInfo
- Publication number
- CN116297843A CN116297843A CN202310277563.4A CN202310277563A CN116297843A CN 116297843 A CN116297843 A CN 116297843A CN 202310277563 A CN202310277563 A CN 202310277563A CN 116297843 A CN116297843 A CN 116297843A
- Authority
- CN
- China
- Prior art keywords
- driving
- driving device
- detection
- ultrasonic testing
- ring forging
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images





Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01N—INVESTIGATING OR ANALYSING MATERIALS BY DETERMINING THEIR CHEMICAL OR PHYSICAL PROPERTIES
- G01N29/00—Investigating or analysing materials by the use of ultrasonic, sonic or infrasonic waves; Visualisation of the interior of objects by transmitting ultrasonic or sonic waves through the object
- G01N29/04—Analysing solids
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01N—INVESTIGATING OR ANALYSING MATERIALS BY DETERMINING THEIR CHEMICAL OR PHYSICAL PROPERTIES
- G01N29/00—Investigating or analysing materials by the use of ultrasonic, sonic or infrasonic waves; Visualisation of the interior of objects by transmitting ultrasonic or sonic waves through the object
- G01N29/22—Details, e.g. general constructional or apparatus details
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01N—INVESTIGATING OR ANALYSING MATERIALS BY DETERMINING THEIR CHEMICAL OR PHYSICAL PROPERTIES
- G01N29/00—Investigating or analysing materials by the use of ultrasonic, sonic or infrasonic waves; Visualisation of the interior of objects by transmitting ultrasonic or sonic waves through the object
- G01N29/22—Details, e.g. general constructional or apparatus details
- G01N29/26—Arrangements for orientation or scanning by relative movement of the head and the sensor
- G01N29/275—Arrangements for orientation or scanning by relative movement of the head and the sensor by moving both the sensor and the material
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01N—INVESTIGATING OR ANALYSING MATERIALS BY DETERMINING THEIR CHEMICAL OR PHYSICAL PROPERTIES
- G01N2291/00—Indexing codes associated with group G01N29/00
- G01N2291/02—Indexing codes associated with the analysed material
- G01N2291/023—Solids
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02E—REDUCTION OF GREENHOUSE GAS [GHG] EMISSIONS, RELATED TO ENERGY GENERATION, TRANSMISSION OR DISTRIBUTION
- Y02E30/00—Energy generation of nuclear origin
- Y02E30/30—Nuclear fission reactors
Landscapes
- Physics & Mathematics (AREA)
- Health & Medical Sciences (AREA)
- Life Sciences & Earth Sciences (AREA)
- Chemical & Material Sciences (AREA)
- Analytical Chemistry (AREA)
- Biochemistry (AREA)
- General Health & Medical Sciences (AREA)
- General Physics & Mathematics (AREA)
- Immunology (AREA)
- Pathology (AREA)
- Acoustics & Sound (AREA)
- Investigating Or Analyzing Materials By The Use Of Ultrasonic Waves (AREA)
Abstract
Description
技术领域technical field
本发明涉及超声波检测技术领域,尤其涉及一种超声检测设备。The invention relates to the technical field of ultrasonic detection, in particular to an ultrasonic detection device.
背景技术Background technique
环锻件作为盾构主轴承的核心零件之一,在实际应用中承受较高负荷,为保证设备的安全使用,需要对环锻件进行检测。而环锻件尺寸变化大、截面复杂、重量大。尺寸变化大表现为直径3米到9米不等,截面复杂主要体现为各种尺寸的台阶、凹槽,重量最重达30吨。As one of the core parts of the main bearing of the shield machine, the ring forging bears a relatively high load in practical applications. In order to ensure the safe use of the equipment, the ring forging needs to be tested. However, ring forgings have large size changes, complex cross-sections, and heavy weight. The large size change is manifested by the diameter ranging from 3 meters to 9 meters, and the complex cross section is mainly reflected in the steps and grooves of various sizes, and the heaviest weight is 30 tons.
相关技术中,通过人工的方式,手持纵波直探头对环锻件进行检测,包括在外圆周扫查的径向检测和断面扫查的轴向检测。In the related art, the ring forging is inspected manually with a straight longitudinal wave probe, including radial inspection on the outer circumference and axial inspection on the cross-section.
然而,这种检测方式的效率较低。However, the efficiency of this detection method is low.
发明内容Contents of the invention
本发明提供一种超声检测设备,检测效率较高。The invention provides an ultrasonic detection device with high detection efficiency.
本发明提供一种超声检测设备,用于检测环锻件,超声检测设备包括检测容器、第一驱动装置、第二驱动装置、至少两个超声检测装置和控制装置;The present invention provides an ultrasonic testing device for testing ring forgings. The ultrasonic testing device includes a testing container, a first driving device, a second driving device, at least two ultrasonic testing devices and a control device;
检测容器用于容置耦合剂和环锻件,第一驱动装置和第二驱动装置均位于检测容器内,第一驱动装置与检测容器固接,第二驱动装置与检测容器可移动连接,第二驱动装置相对检测容器朝向第一驱动装置移动,以推动环锻件与第一驱动装置抵接,第一驱动装置和第二驱动装置被配置为驱动环锻件绕自身轴线转动;The detection container is used to accommodate the coupling agent and the ring forging, the first driving device and the second driving device are located in the detection container, the first driving device is fixedly connected to the detection container, the second driving device is movably connected to the detection container, and the second The driving device moves toward the first driving device relative to the detection container, so as to push the ring forging to abut against the first driving device, and the first driving device and the second driving device are configured to drive the ring forging to rotate around its own axis;
至少两个超声检测装置位于检测容器的周侧,其中至少一超声检测装置与环锻件的端面抵接,并沿端面移动,至少另一超声检测装置与环锻件的侧面抵接,并沿侧面移动;At least two ultrasonic testing devices are located on the peripheral side of the testing container, wherein at least one ultrasonic testing device abuts against the end face of the ring forging and moves along the end face, and at least another ultrasonic testing device abuts against the side of the ring forging and moves along the side ;
第一驱动装置、第二驱动装置和超声检测装置均与控制装置电连接。The first drive device, the second drive device and the ultrasonic detection device are all electrically connected to the control device.
在一种可能的实现方式中,本发明提供的超声检测设备,第二驱动装置包括两个第一驱动组件和两个第一导轨,两个第一驱动组件与两个第一导轨一一对应可移动连接;In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the second drive device includes two first drive assemblies and two first guide rails, and the two first drive assemblies correspond to the two first guide rails one by one. removable connection;
两个第一导轨与检测容器的内底壁连接,两个第一导轨间隔设置,且延伸方向具有夹角,两个第一导轨位于第一驱动装置的同侧,且沿延伸方向的一端均靠近第一驱动装置,另一端均靠近检测容器的侧壁。The two first guide rails are connected to the inner bottom wall of the detection container, the two first guide rails are arranged at intervals, and the extension direction has an included angle, the two first guide rails are located on the same side of the first driving device, and one end along the extension direction is It is close to the first driving device, and the other end is close to the side wall of the detection container.
在一种可能的实现方式中,本发明提供的超声检测设备,第一驱动组件包括移动小车、第一驱动件、第一传动件、第二驱动件和第二传动件,第一传动件与移动小车转动连接,第一驱动件的驱动轴与第一传动件连接,第一传动件与第一导轨连接,第一驱动件通过第一传动件驱动移动小车沿第一导轨移动;In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the first driving assembly includes a mobile trolley, a first driving member, a first transmission member, a second driving member and a second transmission member, and the first transmission member and The mobile trolley is rotationally connected, the drive shaft of the first driving member is connected to the first transmission member, the first transmission member is connected to the first guide rail, and the first driving member drives the mobile trolley to move along the first guide rail through the first transmission member;
第二传动件与移动小车转动连接,第二驱动件的驱动轴与第二传动件连接,第二驱动件驱动第二传动件转动,且第二传动件用于与环锻件抵接,并驱动环锻件转动。The second transmission part is rotationally connected with the mobile trolley, the drive shaft of the second drive part is connected with the second transmission part, the second drive part drives the second transmission part to rotate, and the second transmission part is used to abut against the ring forging and drive The ring forging turns.
在一种可能的实现方式中,本发明提供的超声检测设备,第一驱动组件还包括第一摩擦件,第一摩擦件套设在第二传动件上,第一摩擦件用于与环锻件抵接,并带动环锻件转动。In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the first driving assembly further includes a first friction member, the first friction member is sleeved on the second transmission member, and the first friction member is used for contacting the ring forging Butt, and drive the ring forging to rotate.
在一种可能的实现方式中,本发明提供的超声检测设备,第二驱动装置还包括两个导向组件,两个导向组件与两个第一导轨一一对应设置,导向组件包括两个第二导轨,两个第二导轨位于对应的第一导轨的相对两侧,且与对应的第一导轨平行设置,移动小车与第二导轨滚动连接。In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the second driving device further includes two guide assemblies, and the two guide assemblies are arranged in one-to-one correspondence with the two first guide rails, and the guide assemblies include two second guide rails. For the guide rails, two second guide rails are located on opposite sides of the corresponding first guide rails, and are arranged in parallel with the corresponding first guide rails, and the mobile trolley is rollingly connected with the second guide rails.
在一种可能的实现方式中,本发明提供的超声检测设备,移动小车包括车体和至少两个导向轮,至少两个导向轮转动设置在车体的相对的两侧,两侧的导向轮之间的间距与同一导向组件中两个第二导轨的间距相等,导向轮与第二导轨滚动连接。In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the mobile trolley includes a car body and at least two guide wheels, at least two guide wheels are rotatably arranged on opposite sides of the car body, and the guide wheels on both sides The distance between them is equal to the distance between two second guide rails in the same guide assembly, and the guide wheels are rollingly connected with the second guide rails.
在一种可能的实现方式中,本发明提供的超声检测设备,第二驱动装置还包括多个支撑组件,各支撑组件位于第一驱动装置的同侧,各支撑组件的延伸方向不同,且各支撑组件沿延伸方向的一端均靠近第一驱动装置,另一端均靠近检测容器的侧壁;In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the second drive device further includes a plurality of support assemblies, each support assembly is located on the same side of the first drive device, the extension directions of each support assembly are different, and each One end of the support assembly along the extension direction is close to the first driving device, and the other end is close to the side wall of the detection container;
支撑组件包括多个沿延伸方向间隔设置的支撑件,支撑件与检测容器的内底壁转动连接。The supporting assembly includes a plurality of supporting pieces arranged at intervals along the extending direction, and the supporting pieces are rotatably connected with the inner bottom wall of the detection container.
在一种可能的实现方式中,本发明提供的超声检测设备,第一驱动装置包括两个间隔设置的第二驱动组件,第二驱动组件包括连接件、第三驱动件、第三传动件和第二摩擦件,连接连与检测容器的内底壁连接,第三传动件与连接件转动连接,第三驱动件的驱动轴与第三传动件连接,第二摩擦件套设在第三传动件上,第三驱动件通过第三传动件驱动第二摩擦件转动,且第二摩擦件用于与环锻件抵接,并带动环锻件转动。In a possible implementation manner, in the ultrasonic testing equipment provided by the present invention, the first driving device includes two second driving assemblies arranged at intervals, and the second driving assembly includes a connecting member, a third driving member, a third transmission member and The second friction part is connected to the inner bottom wall of the detection container, the third transmission part is connected to the connection part in rotation, the driving shaft of the third driving part is connected to the third transmission part, and the second friction part is sleeved on the third transmission part. On the part, the third driving part drives the second friction part to rotate through the third transmission part, and the second friction part is used to abut against the ring forging and drive the ring forging to rotate.
在一种可能的实现方式中,本发明提供的超声检测设备,还包括探伤定位装置,探伤定位装置包括定位件、第一检测件和第二检测件,第一检测件和定位件中的一者与第一驱动组件连接,另一者用于与环锻件连接,第一检测件被配置为检测定位件;In a possible implementation manner, the ultrasonic testing equipment provided by the present invention further includes a flaw detection positioning device, the flaw detection positioning device includes a positioning piece, a first detection piece and a second detection piece, and one of the first detection piece and the positioning piece One is connected to the first drive assembly, the other is used to connect with the ring forging, and the first detection part is configured to detect the positioning part;
第二检测件与第二驱动件连接,第二检测件被配置为检测第二驱动件的转速,第一检测件和第二检测件均与控制装置电连接。The second detecting part is connected with the second driving part, and the second detecting part is configured to detect the rotation speed of the second driving part, and both the first detecting part and the second detecting part are electrically connected with the control device.
在一种可能的实现方式中,本发明提供的超声检测设备,还包括泵站,泵站与控制装置电连接,且泵站与检测容器连通。In a possible implementation manner, the ultrasonic testing equipment provided by the present invention further includes a pumping station, the pumping station is electrically connected to the control device, and the pumping station is in communication with the detection container.
本发明提供的超声检测设备,通过设置检测容器、第一驱动装置、第二驱动装置、至少两个超声检测装置和控制装置。检测容器用于容置耦合剂和环锻件,从而实现全水浸检测。第一驱动装置和第二驱动装置均位于检测容器内,第一驱动装置与检测容器固接,第二驱动装置与检测容器可移动连接,第二驱动装置相对检测容器朝向第一驱动装置移动,以推动环锻件与第一驱动装置抵接,这样,超声检测设备可以对不同尺寸的环锻件进行检测。第一驱动装置和第二驱动装置驱动环锻件绕自身轴线转动,至少一超声检测装置与环锻件的端面抵接,并沿端面移动,至少一超声检测装置与环锻件的侧面抵接,并沿侧面移动,可以实现对环锻件多个检测方向的自动检测,第一驱动装置、第二驱动装置和超声检测装置均与控制装置电连接,控制装置可以记录检测数据,并根据标准要求进行分析技术对缺陷定量、评级,最终输出探伤报告。因此,超声检测设备的检测效率较高。The ultrasonic testing equipment provided by the present invention is provided with a testing container, a first driving device, a second driving device, at least two ultrasonic testing devices and a control device. The test container is used to hold the couplant and ring forgings, so as to realize the full water immersion test. Both the first drive device and the second drive device are located in the detection container, the first drive device is fixedly connected to the detection container, the second drive device is movably connected to the detection container, and the second drive device moves toward the first drive device relative to the detection container, The ring forging is pushed to abut against the first driving device, so that the ultrasonic testing equipment can detect ring forgings of different sizes. The first driving device and the second driving device drive the ring forging to rotate around its own axis, at least one ultrasonic detection device abuts against the end face of the ring forging, and moves along the end face, at least one ultrasonic detection device abuts against the side of the ring forging, and moves along the end face The side movement can realize automatic detection of multiple detection directions of ring forgings. The first drive device, the second drive device and the ultrasonic detection device are all electrically connected to the control device. The control device can record the detection data and analyze the technology according to the standard requirements. Quantify and grade defects, and finally output flaw detection reports. Therefore, the detection efficiency of ultrasonic testing equipment is relatively high.
附图说明Description of drawings
为了更清楚地说明本发明实施例或现有技术中的技术方案,下面将对实施例或现有技术描述中所需要使用的附图作一简单地介绍,显而易见地,下面描述中的附图是本发明的一些实施例,对于本领域普通技术人员来讲,在不付出创造性劳动的前提下,还可以根据这些附图获得其他的附图。In order to more clearly illustrate the technical solutions in the embodiments of the present invention or the prior art, the following will briefly introduce the drawings that need to be used in the description of the embodiments or the prior art. Obviously, the accompanying drawings in the following description These are some embodiments of the present invention. Those skilled in the art can also obtain other drawings based on these drawings without creative work.
图1为本发明实施例提供的超声检测设备的结构示意图;FIG. 1 is a schematic structural diagram of an ultrasonic testing device provided by an embodiment of the present invention;
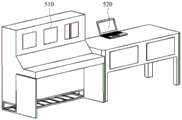
图2为本发明实施例提供的超声检测设备中控制装置的结构示意图;2 is a schematic structural diagram of a control device in an ultrasonic testing device provided by an embodiment of the present invention;
图3为本发明实施例提供的超声检测设备中超声检测装置的结构示意图;3 is a schematic structural diagram of an ultrasonic testing device in an ultrasonic testing device provided by an embodiment of the present invention;
图4为本发明实施例提供的超声检测设备中检测容器和第二驱动装置的俯视图;Fig. 4 is a top view of the testing container and the second driving device in the ultrasonic testing equipment provided by the embodiment of the present invention;
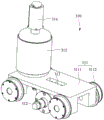
图5为本发明实施例提供的超声检测设备中第一驱动组件的结构示意图;Fig. 5 is a schematic structural diagram of the first drive assembly in the ultrasonic testing device provided by the embodiment of the present invention;
图6为本发明实施例提供的超声检测设备中第二驱动组件的结构示意图;Fig. 6 is a schematic structural diagram of a second drive assembly in an ultrasonic testing device provided by an embodiment of the present invention;
图7为本发明实施例提供的超声检测设备中第一驱动组件和探伤定位装置的结构示意图;Fig. 7 is a schematic structural diagram of the first driving assembly and the flaw detection positioning device in the ultrasonic testing equipment provided by the embodiment of the present invention;
图8为本发明实施例提供的超声检测设备中第一驱动组件和探伤定位装置的使用状态示意图。Fig. 8 is a schematic diagram of the use state of the first driving assembly and the flaw detection positioning device in the ultrasonic testing equipment provided by the embodiment of the present invention.
附图标记说明:Explanation of reference signs:
100-检测容器;200-第一驱动装置;210-第二驱动组件;211-连接件;212-第三驱动件;213-第二摩擦件;300-第二驱动装置;310-第一驱动组件;311-移动小车;3111-车体;3112-导向轮;312-第一驱动件;313-第一传动件;314-第二驱动件;315-第一摩擦件;320-第一导轨;330-导向组件;331-第二导轨;340-支撑组件;341-支撑件;400-超声检测装置;410-机械臂;420-探伤探头;430-探伤检测数据收发装置;500-控制装置;510-电脑;520-电控操作台;600-泵站;700-探伤定位装置;710-定位件;720-第一检测件;730-第二检测件;800-环锻件。100-detection container; 200-first drive device; 210-second drive assembly; 211-connector; 212-third drive member; 213-second friction member; 300-second drive device; 310-first drive Components; 311-moving trolley; 3111-car body; 3112-guide wheel; 312-first drive member; 313-first drive member; 314-second drive member; 315-first friction member; 320-first guide rail ;330-guide assembly; 331-second guide rail; 340-support assembly; 341-support; 400-ultrasonic testing device; 410-mechanical arm; 420-flaw detection probe; ;510-computer; 520-electric control console; 600-pumping station; 700-flaw detection positioning device;
具体实施方式Detailed ways
在本发明的描述中,除非另有明确的规定和限定,术语“安装”、“相连”、“连接”应作广义理解,例如,可以是固定连接,也可以是通过中间媒介间接相连,可以是两个元件内部的连通或者两个元件的相互作用关系。对于本领域的普通技术人员而言,可以根据具体情况理解上述术语在本发明中的具体含义。In the description of the present invention, unless otherwise clearly specified and limited, the terms "installation", "connection" and "connection" should be understood in a broad sense, for example, it may be a fixed connection, or an indirect connection through an intermediary, or It is the connection between two elements or the interaction relationship between two elements. Those of ordinary skill in the art can understand the specific meanings of the above terms in the present invention according to specific situations.
在本发明的描述中,术语“上”、“下”、“前”、“后”、“竖直”、“水平”、“顶”、“底”、“内”、“外”等指示的方位或者位置关系为基于附图所示的方位或位置关系,仅是为了便于描述本发明和简化描述,而不是指示或者暗示所指的装置或者元件必须具有特定的方位、以特定的方位构造和操作,因此不能理解为对本发明的限制。In the description of the present invention, the terms "upper", "lower", "front", "rear", "vertical", "horizontal", "top", "bottom", "inner", "outer" etc. indicate The orientation or positional relationship is based on the orientation or positional relationship shown in the drawings, which is only for the convenience of describing the present invention and simplifying the description, and does not indicate or imply that the referred device or element must have a specific orientation or be configured in a specific orientation. and operation, and therefore should not be construed as limiting the invention.
本发明的说明书和权利要求书及上述附图中的术语“第一”、“第二”、“第三”(如果存在)是用于区别类似的对象,而不必用于描述特定的顺序或先后次序。应该理解这样使用的数据在适当情况下可以互换,以便这里描述的本发明的实施例例如能够以除了在这里图示或描述的那些以外的顺序实施。The terms "first", "second", and "third" (if any) in the description and claims of the present invention and the above drawings are used to distinguish similar objects and not necessarily to describe a specific order or priority. It is to be understood that the data so used are interchangeable under appropriate circumstances such that the embodiments of the invention described herein are, for example, capable of practice in sequences other than those illustrated or described herein.
此外,术语“包括”和“具有”以及他们的任何变形,意图在于覆盖不排他的包含,例如,包含了一系列步骤或单元的过程、方法、系统、产品或维护工具不必限于清楚地列出的那些步骤或单元,而是可包括没有清楚地列出的或对于这些过程、方法、产品或维护工具固有的其它步骤或单元。Furthermore, the terms "comprising" and "having", as well as any variations thereof, are intended to cover a non-exclusive inclusion, for example, a process, method, system, product or maintenance tool comprising a series of steps or units need not be limited to the expressly listed Instead, other steps or elements not explicitly listed or inherent to the process, method, product or maintenance tool may be included.
为使本发明实施例的目的、技术方案和优点更加清楚,下面将结合本发明实施例中的附图,对本发明实施例中的技术方案进行清楚、完整地描述,显然,所描述的实施例是本发明一部分实施例,而不是全部的实施例。基于本发明中的实施例,本领域普通技术人员在没有作出创造性劳动前提下所获得的所有其他实施例,都属于本发明保护的范围。In order to make the purpose, technical solutions and advantages of the embodiments of the present invention clearer, the technical solutions in the embodiments of the present invention will be clearly and completely described below in conjunction with the drawings in the embodiments of the present invention. Obviously, the described embodiments It is a part of embodiments of the present invention, but not all embodiments. Based on the embodiments of the present invention, all other embodiments obtained by persons of ordinary skill in the art without creative efforts fall within the protection scope of the present invention.
锻造是指对金属材料施加压为或冲击力,使其发生塑性变形,成为所需几何形状与尺寸以及组织性能的金属毛坯或零件的方法,故也称作压力加工,所制成的工件就是锻件。锻件是由热态钢锭经过锻压而成,在生产过程中会存在一些缺陷。锻件是各种机械设备及锅炉容器的重要毛坯件。在实际应用中承受较高负荷,为保证设备的安全使用,运用检测技术对锻件进行检测是最实用的。按超声波探伤标准《GB/T37400.15重型机械通用技术条件第15部分:锻钢件无损探伤》进行100%UT检测(Ultrasonic Testing,超声检测),满足质量等级Ⅰ级为合格。Forging refers to the method of applying pressure or impact force to a metal material to cause it to undergo plastic deformation and become a metal blank or part with the required geometric shape, size and organizational properties, so it is also called pressure processing. The workpiece is Forgings. Forgings are formed by forging and pressing hot steel ingots, and there will be some defects in the production process. Forgings are important blanks for various mechanical equipment and boiler vessels. In practical applications, it bears a relatively high load. In order to ensure the safe use of equipment, it is most practical to use detection technology to detect forgings. 100% UT testing (Ultrasonic Testing, ultrasonic testing) is carried out according to the ultrasonic flaw detection standard "GB/T37400.15 General Technical Conditions for Heavy Machinery Part 15: Nondestructive Testing of Forged Steel Parts", and it is qualified if it meets the quality level I.
地下施工装备盾构根据设计要求开挖断面尺寸很大,直径有3米-25米不等。盾构的开挖直径、施工工况、不同的地质条件要求盾构设计必须是定制化、个性化的设计和制造。因此,环锻件作为盾构主轴承的核心零件之一,其主要特点为尺寸变化大、截面复杂、重量大。尺寸变化大表现为直径3米到9米不等,截面复杂主要体现为各种尺寸的台阶、凹槽,重量最重达30吨。上述特点给环锻件的探伤带来了如下困难:According to the design requirements, the excavation section of the underground construction equipment shield is very large, with a diameter ranging from 3 meters to 25 meters. The excavation diameter, construction conditions, and different geological conditions of the shield require that the design of the shield must be customized and personalized. Therefore, as one of the core parts of the main bearing of the shield machine, the ring forging is mainly characterized by large size changes, complex cross-sections, and heavy weight. The large size change is manifested by the diameter ranging from 3 meters to 9 meters, and the complex cross section is mainly reflected in the steps and grooves of various sizes, and the heaviest weight is 30 tons. The above characteristics bring the following difficulties to the flaw detection of ring forgings:
(1)锻件毛坯规格多样、截面复杂,检测量巨大。环锻件常规探伤采用纵波直探头进行两个个方向的扫查,包括在外圆周扫查的径向检测和断面扫查的轴向检测。人工扫查只能在两个方向步进扫查,检测效率低下,8-9米级复杂环锻件的扫查大致需要一个班。(1) Forging blanks have various specifications and complex cross-sections, and the detection volume is huge. For conventional flaw detection of ring forgings, longitudinal wave straight probes are used to scan in two directions, including radial detection on the outer circumference and axial detection on cross-section scanning. Manual scanning can only scan step by step in two directions, and the detection efficiency is low. The scanning of 8-9 meter complex ring forgings generally requires one shift.
(2)超声波探伤高度依赖操作者的技能和责任心,存在漏检、缺陷定量不准确、评级不准等不确定性。(2) Ultrasonic flaw detection is highly dependent on the skills and sense of responsibility of the operator, and there are uncertainties such as missed inspections, inaccurate defect quantification, and inaccurate ratings.
(3)检测数据、结果不能存储,检测过程可追溯性差。(3) The test data and results cannot be stored, and the traceability of the test process is poor.
因此,人工检测不能满足轴承关键零件环锻件批量生产的检测需求,已成为生产中的瓶颈工序。Therefore, manual inspection cannot meet the inspection requirements of mass production of ring forgings, a key part of bearings, and has become a bottleneck process in production.
为了解决上述技术问题,本发明提供一种超声检测设备,利用检测容置容置环锻件和耦合剂,从而实现全水浸检测。通过第一驱动装置和第二驱动装置夹紧定位环锻件,并驱动环锻件转动。利用一超声检测装置与环锻件的端面抵接,并沿端面移动,一超声检测装置与环锻件的侧面抵接,并沿侧面移动。这样,通过环锻件的转动和超声检测装置在环锻件表面的移动,从而实现多个检测方向的自动检测,效率较高。其中,超声检测装置在环锻件表面的移动路径可以由控制装置控制,而且,控制装置可以记录检测数据,并根据标准要求进行分析技术对缺陷定量、评级,最终输出探伤报告。其中,第二驱动装置与检测容器可移动连接,通过调整第二驱动装置的位置,第一驱动装置和第二驱动装置可以夹紧定位不同直径尺寸的环锻件,并驱动环锻件转动。因此,超声检测设备可以对不同尺寸的环锻件进行检测。In order to solve the above-mentioned technical problems, the present invention provides an ultrasonic testing device, which utilizes the detection and containment ring forging and coupling agent to realize full water immersion detection. The ring forging is clamped and positioned by the first driving device and the second driving device, and the ring forging is driven to rotate. An ultrasonic detection device abuts against the end face of the ring forging and moves along the end face, and an ultrasonic detection device abuts against the side of the ring forging and moves along the side. In this way, through the rotation of the ring forging and the movement of the ultrasonic detection device on the surface of the ring forging, automatic detection of multiple detection directions is realized, and the efficiency is high. Among them, the moving path of the ultrasonic testing device on the surface of the ring forging can be controlled by the control device, and the control device can record the detection data, perform analysis techniques to quantify and grade defects according to standard requirements, and finally output a flaw detection report. Wherein, the second driving device is movably connected with the detection container, and by adjusting the position of the second driving device, the first driving device and the second driving device can clamp and position ring forgings with different diameters, and drive the ring forgings to rotate. Therefore, ultrasonic testing equipment can test ring forgings of different sizes.
图1为本发明实施例提供的超声检测设备的结构示意图。Fig. 1 is a schematic structural diagram of an ultrasonic testing device provided by an embodiment of the present invention.
参见图1所示,本发明提供的超声检测设备,用于检测环锻件800,超声检测设备包括检测容器100、第一驱动装置200、第二驱动装置300、至少两个超声检测装置400和控制装置500。Referring to Fig. 1, the ultrasonic testing equipment provided by the present invention is used for testing a ring forging 800. The ultrasonic testing equipment includes a
其中,检测容器100用于容置耦合剂和环锻件800。需要说明的是,为了实现全水浸检测,耦合剂需要浸没环锻件800。Wherein, the
示例性的,耦合剂可以为水、甘油或者机油。Exemplarily, the coupling agent can be water, glycerin or engine oil.
示例性的,检测容器100尺寸为Φ10.28m×1.22m,可满足Φ2-9m工件试验,最大静承载50t,检测容器100的底部预留接口用于耦合剂的替换清理,且检测容器100的内底面的平面度±0.2mm。Exemplarily, the size of the
其中,第一驱动装置200和第二驱动装置300均位于检测容器100内,第一驱动装置200与检测容器100固接,第二驱动装置300与检测容器100可移动连接,第二驱动装置300相对检测容器100朝向第一驱动装置200移动,第二驱动装置300与环锻件800抵接后继续推动环锻件800朝向第一驱动装置200移动,从而使环锻件800与第一驱动装置200抵接。这样,第一驱动装置200和第二驱动装置300可以夹紧并定位环锻件800。然后,第一驱动装置200和第二驱动装置300驱动环锻件800绕环锻件800自身轴线转动。Wherein, the
其中,至少两个超声检测装置400位于检测容器100的外部,其中至少一超声检测装置400与环锻件800的端面抵接,并沿端面移动,至少一超声检测装置400与环锻件800的侧面抵接,并沿侧面移动。Wherein, at least two
示例性的,超声检测装置400的数量为两个。一个超声检测装置400与环锻件800的端面抵接,在端面沿环锻件800的径向移动。另一个超声检测装置400与环锻件800的侧面抵接,在侧面沿环锻件800的轴向移动。Exemplarily, the number of
其中,第一驱动装置200、第二驱动装置300和超声检测装置400均与控制装置500电连接。Wherein, the
工作时,利用行车平吊环锻件800放置检测容器100内,检测容器100充水淹没环锻件800。第二驱动装置300相对检测容器100朝向第一驱动装置200移动,第二驱动装置300与环锻件800抵接后继续推动环锻件800朝向第一驱动装置200移动,第一驱动装置200和第二驱动装置300可以夹紧并定位环锻件800。在控制装置500中设定待探伤环锻件800截面,控制装置500进行路径规划。启动探伤后,两个超声检测装置400运动至路径起始位置,第一驱动装置200和第二驱动装置300驱动环锻件800绕环锻件800自身轴线转动。环锻件800每旋转一轴,声检测装置步进一定距离扫描或螺旋扫描。控制装置500记录探伤信号、位置信号,并根据标准要求进行分析技术对缺陷定量、评级,最终输出探伤报告。During work, the forging ring 800 is placed in the
本实施例提供的超声检测设备,通过设置检测容器100、第一驱动装置200、第二驱动装置300、至少两个超声检测装置400和控制装置500。检测容器100用于容置耦合剂和环锻件800,从而实现全水浸检测。第一驱动装置200和第二驱动装置300均位于检测容器100内,第一驱动装置200与检测容器100固接,第二驱动装置300与检测容器100可移动连接,第二驱动装置300相对检测容器100朝向第一驱动装置200移动,以推动环锻件800与第一驱动装置200抵接,这样,超声检测设备可以对不同尺寸的环锻件800进行检测。第一驱动装置200和第二驱动装置300驱动环锻件800绕轴线转动,至少一超声检测装置400与环锻件800的端面抵接,并沿端面移动,至少一超声检测装置400与环锻件800的侧面抵接,并沿侧面移动,可以实现对环锻件800多个检测方向的自动检测,第一驱动装置200、第二驱动装置300和超声检测装置400均与控制装置500电连接,控制装置500可以记录检测数据,并根据标准要求进行分析技术对缺陷定量、评级,最终输出探伤报告。因此,超声检测设备的检测效率较高。The ultrasonic testing equipment provided in this embodiment is provided with a
图2为本发明实施例提供的超声检测设备中控制装置的结构示意图。Fig. 2 is a schematic structural diagram of a control device in an ultrasonic testing device provided by an embodiment of the present invention.
参见图2所示,控制装置500包括电脑510和电控操作台520。电脑510和电控操作台520电连接,第一驱动装置200、第二驱动装置300和超声检测装置400均与电控操作台520电连接。Referring to FIG. 2 , the
图3为本发明实施例提供的超声检测设备中超声检测装置的结构示意图。Fig. 3 is a schematic structural diagram of an ultrasonic testing device in an ultrasonic testing device provided by an embodiment of the present invention.
参见图3所示,超声检测装置400包括机械臂410、探伤探头420和探伤检测数据收发装置430。探伤探头420与机械臂410的操作末端连接,探伤检测数据收发装置430与探伤探头420电连接,且与控制装置500电连接。Referring to FIG. 3 , the
参见图1所示,超声检测设备还包括泵站600,泵站600与控制装置500电连接,且泵站600与检测容器100连通。泵站600用于将耦合剂输送到检测容器100中,或者将检测容器100中的耦合剂排出,从而有利于提高检测效率。Referring to FIG. 1 , the ultrasonic testing equipment further includes a pumping station 600 , which is electrically connected to the
图4为本发明实施例提供的超声检测设备中检测容器和第二驱动装置300的俯视图。Fig. 4 is a top view of the testing container and the
参见图1和图4所示,第二驱动装置300包括两个第一驱动组件310和两个第一导轨320,两个第一驱动组件310与两个第一导轨320一一对应可移动连接。1 and 4, the
其中,两个第一导轨320与检测容器100的内底壁连接,两个第一导轨320间隔设置,且延伸方向具有夹角,两个第一导轨320位于第一驱动装置200的同侧,且沿延伸方向的一端均靠近第一驱动装置200,另一端均靠近检测容器100的侧壁。Wherein, the two
可以理解的是,通过设置第一驱动装置200、两个第一驱动组件310和两个第一导轨320,采用三点定心方式,使检测点固定,结构较简单。It can be understood that by arranging the
图5为本发明实施例提供的超声检测设备中第一驱动组件的结构示意图。Fig. 5 is a schematic structural diagram of a first drive assembly in an ultrasonic testing device provided by an embodiment of the present invention.
参见图5所示,第一驱动组件310包括移动小车311、第一驱动件312、第一传动件313、第二驱动件314和第二传动件(图中未示出),第一传动件313与移动小车311转动连接,第一驱动件312的驱动轴与第一传动件313连接,第一传动件313与第一导轨320连接,第一驱动件312通过第一传动件313驱动移动小车311沿第一导轨320移动。5, the
第二传动件与移动小车311转动连接,第二驱动件314的驱动轴与第二传动件连接,第二驱动件314驱动第二传动件转动,且第二传动件用于与环锻件800抵接,并驱动环锻件800转动。The second transmission member is rotationally connected with the
工作时,第一驱动件312驱动第一传动件313转动,第一传动件313沿第一导轨320移动。第二驱动件314驱动第二传动件转动,第二传动件与环锻件800抵接,第二传动件依靠摩擦力带动环锻件800转动。When working, the first driving
在一种可能的实现方式中,第一传动件313可以为齿轮,第一导轨320可以为与齿轮相匹配的齿轨。In a possible implementation manner, the
其中,第一驱动件312为伺服电机。可以理解的是,不同直径环锻件800检测时,由于环锻件800结构强度和重量不同,所需夹紧力大小不同。第一驱动组件310可以通过伺服电机输出扭矩核算夹紧力数值,并保证夹紧力满足工况要求。Wherein, the first driving
示例性的,齿轨尺寸8.3m×0.1m×0.05m,采用高强42CrMo材料调质制作,耐用性好。Exemplarily, the size of the gear rail is 8.3m×0.1m×0.05m, and it is made of high-strength 42CrMo material, which has good durability.
在另一种可能的实现方式中,第一传动件313可以滚轮,第一导轨320可以为轮轨。In another possible implementation manner, the
为了对环锻件800进行保护,减小环锻件800的摩损,同时提高第一驱动组件310与环锻件800之间的摩擦力。第一驱动组件310还包括第一摩擦件315,第一摩擦件315套设在第二传动件上,第一摩擦件315用于与环锻件800抵接,并驱动环锻件800转动。In order to protect the ring forging 800 , the wear of the ring forging 800 is reduced, and at the same time, the frictional force between the
具体的,第一摩擦件315可以为橡胶套,橡胶套的材质可以为聚氨酯。Specifically, the
为了提高对第一驱动组件310的导向效果,第二驱动装置300还包括两个导向组件330,两个导向组件330与两个第一导轨320一一对应设置,导向组件330包括两个第二导轨331,两个第二导轨331位于对应的第一导轨320的相对两侧,且与对应的第一导轨320平行设置,移动小车311与第二导轨331滚动连接。In order to improve the guiding effect of the
示例性的,导轨尺寸8.1m×0.15m×0.1m×0.05m,标准50钢轨,采用高强45Mn材料制作,耐磨性好。Exemplarily, the size of the guide rail is 8.1m×0.15m×0.1m×0.05m, and the standard 50 steel rail is made of high-strength 45Mn material with good wear resistance.
在一种可能的实现方式中,移动小车311包括车体3111和至少两个导向轮3112,至少两个导向轮3112转动设置在车体3111的相对的两侧,两侧的导向轮3112之间的间距与同一导向组件330中两个第二导轨331的间距相等,导向轮3112与第二导轨331滚动连接。In a possible implementation, the
具体的,参见图5所示,导向轮3112的数量可以为四个,四个导向轮3112对称设置在车体3111的相对的两侧。Specifically, as shown in FIG. 5 , the number of
参见图1和图4所示所示,为了减小环锻件800与检测容器100的摩擦力,第二驱动装置300还包括多个支撑组件340,各支撑组件340位于第一驱动装置200的同侧,各支撑组件340的延伸方向不同,且各支撑组件340沿延伸方向的一端均靠近第一驱动装置200,另一端均靠近检测容器100的侧壁。1 and 4, in order to reduce the friction between the ring forging 800 and the
具体的,支撑组件340包括多个沿延伸方向间隔设置的支撑件341,支撑件341与检测容器100的内底壁转动连接。Specifically, the
具体的,支撑件341可以为万向球。Specifically, the
示例性的,万向球为SP-150精密重载万向球,整体尺寸φ240mm×300mm,球直径150mm,单体载重6t。Exemplarily, the universal ball is a SP-150 precision heavy-duty universal ball, with an overall size of φ240mm×300mm, a ball diameter of 150mm, and a single load of 6t.
可以理解的是,支撑件341呈放射状排布,有利于增加支撑件341与环锻件800的接触数量,增加支撑件341与环锻件800的接触面积。It can be understood that the radial arrangement of the
图6为本发明实施例提供的超声检测设备中第二驱动组件的结构示意图。Fig. 6 is a schematic structural diagram of the second drive assembly in the ultrasonic testing device provided by the embodiment of the present invention.
参见图6所示,第一驱动装置200包括两个间隔设置的第二驱动组件210,第二驱动组件210包括连接件211、第三驱动件212、第三传动件(图中未示出)和第二摩擦件213,连接连与检测容器100的内底壁连接,第三传动件与连接件211转动连接,第三驱动件212的驱动轴与第三传动件连接,第二摩擦件213套设在第三传动件上,第三驱动件212通过第三传动件驱动第二摩擦件213转动,且第二摩擦件213用于与环锻件800抵接,并驱动环锻件800转动。6, the
可以理解的是,相比较于设置一个第二驱动组件210,两个第二驱动组件210可以增加对环锻件800的夹紧力,增加对环锻件800的驱动能力。其中,第二摩擦件213的作用与第一摩擦件315作用相同,本实施例在此不做赘述。It can be understood that, compared with setting one
图7为本发明实施例提供的超声检测设备中第一驱动组件和探伤定位装置的结构示意图,图8为本发明实施例提供的超声检测设备中第一驱动组件和探伤定位装置的使用状态示意图。Fig. 7 is a schematic structural diagram of the first driving assembly and flaw detection and positioning device in the ultrasonic testing equipment provided by the embodiment of the present invention, and Fig. 8 is a schematic diagram of the use state of the first driving assembly and the flaw detection and positioning device in the ultrasonic testing equipment provided by the embodiment of the present invention .
参见图7和图8所示,在一种可能的实现方式中,本发明提供的超声检测设备还包括探伤定位装置700,探伤定位装置700包括定位件710、第一检测件720和第二检测件730,第一检测件720和定位件710中的一者与第一驱动组件310连接,另一者用于与环锻件800连接,第一检测件720被配置为检测定位件710。Referring to Figures 7 and 8, in a possible implementation, the ultrasonic testing equipment provided by the present invention further includes a flaw
第二检测件730与第二驱动件314连接,第二检测件730被配置为检测第二驱动件314的转速,第一检测件720和第二检测件730均与控制装置500电连接。The
需要说明的是,探伤定位装置700的数量为1个,探伤定位装置700可以设置在两个第一驱动组件310中的任一者上。It should be noted that the number of the flaw detection and
具体的,第二检测件730为编码器。第一检测件720为接近开关,定位件710为贴片。Specifically, the
工作时,需对探伤结果和环锻件800位置进行基本拟合,快速定位缺陷大致区域。由于环锻件800放置在万向球上,摩擦系数较小,且夹紧力保证第一摩擦件315与环锻件800接触完全,二者相对运动可忽略。通过编码器监测环锻件800回转线速度,进而标定环锻件800运行路程。在回转起始位置粘贴贴片,通过接近开关收发信号确定转一圈时间,与工件运行路程相互验证,基本定位缺陷位置。When working, it is necessary to basically fit the flaw detection results and the position of the ring forging 800, and quickly locate the approximate area of the defect. Since the ring forging 800 is placed on the universal ball, the coefficient of friction is small, and the clamping force ensures complete contact between the
最后应说明的是:以上各实施例仅用以说明本发明的技术方案,而非对其限制;尽管参照前述各实施例对本发明进行了详细的说明,本领域的普通技术人员应当理解:其依然可以对前述各实施例所记载的技术方案进行修改,或者对其中部分或者全部技术特征进行等同替换;而这些修改或者替换,并不使相应技术方案的本质脱离本发明各实施例技术方案的范围。Finally, it should be noted that: the above embodiments are only used to illustrate the technical solutions of the present invention, rather than limiting them; although the present invention has been described in detail with reference to the foregoing embodiments, those of ordinary skill in the art should understand that: It is still possible to modify the technical solutions described in the foregoing embodiments, or perform equivalent replacements for some or all of the technical features; and these modifications or replacements do not make the essence of the corresponding technical solutions deviate from the technical solutions of the various embodiments of the present invention. scope.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202310277563.4A CN116297843B (en) | 2023-03-20 | 2023-03-20 | Ultrasonic detection equipment |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202310277563.4A CN116297843B (en) | 2023-03-20 | 2023-03-20 | Ultrasonic detection equipment |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN116297843A true CN116297843A (en) | 2023-06-23 |
| CN116297843B CN116297843B (en) | 2025-12-09 |
Family
ID=86781232
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202310277563.4A Active CN116297843B (en) | 2023-03-20 | 2023-03-20 | Ultrasonic detection equipment |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN116297843B (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120522293A (en) * | 2025-07-22 | 2025-08-22 | 山西天宝集团有限公司 | Device and method for automatic water-immersion ultrasonic detection of ring forgings of wind turbine generator sets |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO1990013814A1 (en) * | 1989-05-01 | 1990-11-15 | Hamersley Iron Pty. Limited | Ultrasonic wheel testing |
| CN110243933A (en) * | 2019-04-19 | 2019-09-17 | 武汉理工大学 | A kind of detection device and ring detection method for large ring |
| CN110441392A (en) * | 2019-07-29 | 2019-11-12 | 武汉理工大学 | An orbital ultrasonic testing device and ring testing method for large rings |
| CN111796028A (en) * | 2020-07-28 | 2020-10-20 | 武汉理工大学 | Ultrasonic water immersion automatic detection device and method for complex ring forgings |
| CN216695578U (en) * | 2022-01-28 | 2022-06-07 | 中国铁建重工集团股份有限公司 | Large-scale bearing testing arrangement |
| CN115684357A (en) * | 2022-12-30 | 2023-02-03 | 四川鑫跃鑫科学仪器有限公司 | Ultrasonic non-destructive testing device |
-
2023
- 2023-03-20 CN CN202310277563.4A patent/CN116297843B/en active Active
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO1990013814A1 (en) * | 1989-05-01 | 1990-11-15 | Hamersley Iron Pty. Limited | Ultrasonic wheel testing |
| CN110243933A (en) * | 2019-04-19 | 2019-09-17 | 武汉理工大学 | A kind of detection device and ring detection method for large ring |
| CN110441392A (en) * | 2019-07-29 | 2019-11-12 | 武汉理工大学 | An orbital ultrasonic testing device and ring testing method for large rings |
| CN111796028A (en) * | 2020-07-28 | 2020-10-20 | 武汉理工大学 | Ultrasonic water immersion automatic detection device and method for complex ring forgings |
| CN216695578U (en) * | 2022-01-28 | 2022-06-07 | 中国铁建重工集团股份有限公司 | Large-scale bearing testing arrangement |
| CN115684357A (en) * | 2022-12-30 | 2023-02-03 | 四川鑫跃鑫科学仪器有限公司 | Ultrasonic non-destructive testing device |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120522293A (en) * | 2025-07-22 | 2025-08-22 | 山西天宝集团有限公司 | Device and method for automatic water-immersion ultrasonic detection of ring forgings of wind turbine generator sets |
Also Published As
| Publication number | Publication date |
|---|---|
| CN116297843B (en) | 2025-12-09 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102830158B (en) | Bend pipe damage scanning and detecting apparatus based on magnetic memory effect | |
| CN201344919Y (en) | Automated ultrasonic defect detecting device for axle of track traffic vehicle | |
| CN118003030B (en) | Repair welding system for spiral steel pipe and repair welding method thereof | |
| CN110441392A (en) | An orbital ultrasonic testing device and ring testing method for large rings | |
| CN104330473A (en) | Ultrasonic flaw detection device for variable-cross-section shaft-disc type workpieces | |
| CN104897782B (en) | Connection in series-parallel automated ultrasonic flaw detecting and defect recheck equipment | |
| CN110701984A (en) | A comprehensive detection system for the structural strength of a destructive camshaft and its use method | |
| CN102759577A (en) | Phased ultrasonic automatic detecting and positioning system for trunnion ring weld of steel ladle | |
| CN204241426U (en) | A kind of reflectoscope of non-uniform shaft disc type work | |
| CN116297843B (en) | Ultrasonic detection equipment | |
| CN102288677B (en) | Ultrasonic flaw detector for wind-driven power-generating rotary support bearing | |
| CN213121735U (en) | Ultrasonic C-scan scan tooling with automatic scan function | |
| CN105866236B (en) | Tooth surfaces of bevel gears grinding burn automatic detection device and detection method | |
| CN114653623A (en) | Drill bit defect detecting and sorting equipment | |
| CN211478159U (en) | Multilayer metal bearing interface bonding defect ultrasonic penetration detection equipment | |
| CN202693532U (en) | Phased-array ultrasonic automatic detecting and locating system of ladle trunnion ring weld joint | |
| CN204740235U (en) | Automatic ultrasonic inspection of connection in series -parallel and defect reinspection equipment | |
| US12345655B1 (en) | Subsurface defect detecting device for cylindrical components and method thereof | |
| CN111545983A (en) | Automatic labeling mechanism for straight weld joint of short pipe of stainless steel welded pipe | |
| CN114322901A (en) | Universal joint shell curved surface detection device | |
| JP4284762B2 (en) | Evaluation method of sliding member for highly reliable toroidal continuously variable transmission | |
| CN201754153U (en) | Automatic flaw detection device | |
| CN204314258U (en) | For the ultrasound wave on-line checkingi defect-detecting equipment of drill pipe thickening district and friction welding seam | |
| CN2427808Y (en) | Automatic ultrasonic detector for tube (pipe) material | |
| CN114791464A (en) | Portable ultrasonic line inspection detection equipment |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |