CN116142811A - Container operating mechanism, container palletizing system and control method thereof - Google Patents
Container operating mechanism, container palletizing system and control method thereof Download PDFInfo
- Publication number
- CN116142811A CN116142811A CN202111402212.9A CN202111402212A CN116142811A CN 116142811 A CN116142811 A CN 116142811A CN 202111402212 A CN202111402212 A CN 202111402212A CN 116142811 A CN116142811 A CN 116142811A
- Authority
- CN
- China
- Prior art keywords
- container
- palletizing
- assembly
- target position
- pick
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
- 230000007246 mechanism Effects 0.000 title claims abstract description 175
- 238000000034 method Methods 0.000 title claims abstract description 35
- 238000001514 detection method Methods 0.000 description 43
- 238000003860 storage Methods 0.000 description 15
- 238000001179 sorption measurement Methods 0.000 description 11
- 230000009471 action Effects 0.000 description 7
- 239000000126 substance Substances 0.000 description 7
- 230000006870 function Effects 0.000 description 6
- 230000000712 assembly Effects 0.000 description 5
- 238000000429 assembly Methods 0.000 description 5
- 230000001960 triggered effect Effects 0.000 description 5
- 230000000903 blocking effect Effects 0.000 description 3
- 239000000969 carrier Substances 0.000 description 3
- 238000009434 installation Methods 0.000 description 3
- 230000032258 transport Effects 0.000 description 3
- 238000005452 bending Methods 0.000 description 2
- 230000000875 corresponding effect Effects 0.000 description 2
- 239000004744 fabric Substances 0.000 description 2
- 230000000670 limiting effect Effects 0.000 description 2
- 239000002184 metal Substances 0.000 description 2
- 239000000047 product Substances 0.000 description 2
- 230000005236 sound signal Effects 0.000 description 2
- 230000004075 alteration Effects 0.000 description 1
- 230000008901 benefit Effects 0.000 description 1
- 230000003139 buffering effect Effects 0.000 description 1
- -1 cartons Substances 0.000 description 1
- 239000003086 colorant Substances 0.000 description 1
- 238000004891 communication Methods 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 239000012467 final product Substances 0.000 description 1
- 230000014509 gene expression Effects 0.000 description 1
- 239000011521 glass Substances 0.000 description 1
- 230000008676 import Effects 0.000 description 1
- 230000006872 improvement Effects 0.000 description 1
- 238000003780 insertion Methods 0.000 description 1
- 230000037431 insertion Effects 0.000 description 1
- 239000010985 leather Substances 0.000 description 1
- 238000004519 manufacturing process Methods 0.000 description 1
- 239000000463 material Substances 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 238000005192 partition Methods 0.000 description 1
- 230000035515 penetration Effects 0.000 description 1
- 230000008569 process Effects 0.000 description 1
- 238000012545 processing Methods 0.000 description 1
- 239000003351 stiffener Substances 0.000 description 1
- 238000009423 ventilation Methods 0.000 description 1
- 238000003466 welding Methods 0.000 description 1
Images




Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G61/00—Use of pick-up or transfer devices or of manipulators for stacking or de-stacking articles not otherwise provided for
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G43/00—Control devices, e.g. for safety, warning or fault-correcting
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G47/00—Article or material-handling devices associated with conveyors; Methods employing such devices
- B65G47/74—Feeding, transfer, or discharging devices of particular kinds or types
- B65G47/90—Devices for picking-up and depositing articles or materials
- B65G47/91—Devices for picking-up and depositing articles or materials incorporating pneumatic, e.g. suction, grippers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G57/00—Stacking of articles
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Warehouses Or Storage Devices (AREA)
Abstract
本发明公开了一种容器操作机构、包括该容器操作机构的容器码垛系统以及该系统的控制方法。本发明的容器操作机构在容器取放组件取出容器之后,先利用容器位置调整机构将容器调整至预设的第二目标位置处,然后容器码垛组件才从第二目标位置上取出该容器码放在托盘上,将容器码垛组件与容器之间的结合位置限定在允许的偏差范围之内,从而能使容器码垛组件可以将容器的码放位置控制在预设的码放位置处,或者可以将容器的实际码放位置与预设的码放位置之间的偏差量控制在允许的偏差范围之内,避免了该容器与在先码放的容器之间和/或后续待码放的容器之间的位置干涉,保证了码放工作顺畅且有序的进行。

The invention discloses a container operating mechanism, a container stacking system comprising the container operating mechanism and a control method of the system. The container operating mechanism of the present invention uses the container position adjustment mechanism to adjust the container to the preset second target position after the container pick-and-place component takes out the container, and then the container palletizing component takes out the container from the second target position and stacks it. On the pallet, the combined position between the container palletizing assembly and the container is limited within the allowable deviation range, so that the container palletizing assembly can control the stacking position of the container at the preset stacking position, or the The deviation between the actual stacking position of the container and the preset stacking position is controlled within the allowable deviation range, avoiding the positional interference between the container and the previous stacked container and/or the subsequent container to be stacked , to ensure the smooth and orderly progress of the stacking work.
Description
技术领域technical field
本发明涉及仓储系统技术领域,特别涉及一种容器操作机构、容器码垛系统及其控制方法。The invention relates to the technical field of storage systems, in particular to a container operating mechanism, a container palletizing system and a control method thereof.
背景技术Background technique
自动化的仓储系统已经越来越多的应用在各种民用及工业的仓储领域,但是,同时也暴露出一些不够人性化及效率低下的问题。Automated warehousing systems have been more and more used in various civil and industrial warehousing fields, but at the same time, some problems that are not humanized and inefficient have been exposed.
比如,目前的仓储系统中从载具上取容器并且将容器码垛等工作均由人工完成,存在费时费力效率低的问题。For example, in the current warehousing system, taking containers from the carrier and palletizing the containers are all done manually, which is time-consuming, labor-intensive and inefficient.
有鉴于此,如何无人化自动取放并且码放容器是本领域技术人员亟待解决的技术问题。In view of this, how to unmanned automatic pick-and-place and stack containers is a technical problem to be solved urgently by those skilled in the art.
发明内容Contents of the invention
本发明为了无人化自动取放并且码放容器,第一方面提供了一种容器操作机构。In order to unmanned automatic pick-and-place and stacking of containers, the present invention provides a container operating mechanism in the first aspect.
本发明的容器操作机构,包括:The container operating mechanism of the present invention comprises:
底座;base;
容器取放组件,所述容器取放组件被构造为用于取出位于第一目标位置上的容器,且将取出的容器放置在容器位置调整机构上,所述容器位置调整机构被配置为用于将容器调整到预设的第二目标位置;a container pick-and-place assembly configured to take out the container at the first target position, and place the taken-out container on the container position adjustment mechanism, the container position adjustment mechanism is configured for adjusting the container to a preset second target position;
容器码垛组件,所述容器码垛组件被构造为用于取出所述第二目标位置上的容器,且将取出的容器码放在第三目标位置;a container palletizing assembly configured to remove the container at the second target location and stack the removed container at a third target location;
运动组件,所述运动组件设置在所述底座上,且被配置为带动所述容器取放组件和所述容器码垛组件运动。A moving assembly, the moving assembly is arranged on the base and is configured to drive the container pick-and-place assembly and the container palletizing assembly to move.
本发明的容器操作机构的一个实施例中,所述容器取放组件被配置为用于通过容器的前端面与容器结合。In one embodiment of the container handling mechanism of the present invention, the container access assembly is configured to engage with the container through the front face of the container.
本发明的容器操作机构的一个实施例中,所述容器码垛组件被配置为用于通过容器的顶面与容器结合。In one embodiment of the container handling mechanism of the present invention, the container palletizing assembly is configured to engage the container via the top surface of the container.
本发明的容器操作机构的一个实施例中,所述容器取放组件通过吸取、推动、夹取、抓取、钩取、抱起、抬升方式中的至少一种取放容器。In one embodiment of the container operating mechanism of the present invention, the container pick-and-place component picks and places the container by at least one of sucking, pushing, clamping, grabbing, hooking, hugging, and lifting.
本发明的容器操作机构的一个实施例中,所述容器码垛组件通过吸取、钩取、抓取方式中的至少一种码放容器。In one embodiment of the container operating mechanism of the present invention, the container palletizing assembly stacks containers by at least one of suction, hooking and grabbing.
本发明的容器操作机构的一个实施例中,所述容器取放组件包括:In one embodiment of the container operating mechanism of the present invention, the container pick-and-place assembly includes:
第一壳体,所述第一壳体设置在所述运动组件上;a first casing, the first casing is arranged on the moving assembly;
第一吸盘,所述第一吸盘设置在所述第一壳体上并且受控于第一真空发生装置用于吸附或松开容器。A first suction cup, the first suction cup is arranged on the first housing and is controlled by the first vacuum generating device for sucking or loosening the container.
本发明的容器操作机构的一个实施例中,所述容器取放组件包括多个所述第一吸盘。In one embodiment of the container operating mechanism of the present invention, the container pick-and-place assembly includes a plurality of first suction cups.
本发明的容器操作机构的一个实施例中,多个所述第一吸盘被分成相互平行设置的至少两排。In one embodiment of the container operating mechanism of the present invention, the plurality of first suction cups are divided into at least two rows arranged parallel to each other.
本发明的容器操作机构的一个实施例中,所述容器取放组件还包括伸缩驱动组件,所述伸缩驱动组件被配置为用于驱动所述第一吸盘相对于所述第一壳体沿取放容器的方向伸缩运动。In one embodiment of the container operating mechanism of the present invention, the container pick-and-place assembly further includes a telescopic drive assembly configured to drive the first suction cup relative to the first casing along the Telescopic movement in the direction of placing the container.
本发明的容器操作机构的一个实施例中,所述伸缩驱动组件包括活塞缸,所述活塞缸的缸体固定在所述壳体上,所述活塞缸的活塞杆伸出至所述壳体外并且连接所述吸盘,所述活塞缸被构造为通入介质后推动所述活塞杆相对于所述缸体伸缩运动。In one embodiment of the container operating mechanism of the present invention, the telescopic drive assembly includes a piston cylinder, the cylinder body of the piston cylinder is fixed on the housing, and the piston rod of the piston cylinder extends out of the housing And the suction cup is connected, and the piston cylinder is configured to push the piston rod to move telescopically relative to the cylinder body after passing through the medium.
本发明的容器操作机构的一个实施例中,所述伸缩驱动组件包括滚珠丝杠螺母机构和电机,所述滚珠丝杠螺母机构的丝杠以可转动的方式连接在所述壳体上并由所述电机驱动转动,所述滚珠丝杠螺母机构的螺母位于所述壳体外并且固定连接所述吸盘。In one embodiment of the container operating mechanism of the present invention, the telescopic drive assembly includes a ball screw nut mechanism and a motor, and the lead screw of the ball screw nut mechanism is rotatably connected to the housing and controlled by The motor is driven to rotate, and the nut of the ball screw nut mechanism is located outside the housing and fixedly connected to the suction cup.
本发明的容器操作机构的一个实施例中,所述容器取放组件还包括承载元件,所述承载元件设置在所述第一壳体上并且位于所述第一吸盘的下方,所述承载元件被构造成用于承载容器。In one embodiment of the container operating mechanism of the present invention, the container pick-and-place assembly further includes a bearing element, the bearing element is arranged on the first housing and located below the first suction cup, and the bearing element Constructed to hold containers.
本发明的容器操作机构的一个实施例中,所述容器取放组件还包括伸缩驱动组件,所述伸缩驱动组件被配置为用于驱动所述第一吸盘相对于所述第一壳体沿取放容器的方向伸缩运动;In one embodiment of the container operating mechanism of the present invention, the container pick-and-place assembly further includes a telescopic drive assembly configured to drive the first suction cup relative to the first casing along the Telescopic movement in the direction of placing the container;
并且所述第一吸盘被构造为位于伸出状态时超出所述承载元件以吸附容器、位于缩回状态时使所述承载元件承载容器。And the first suction cup is configured to exceed the carrier element to absorb the container when it is in the extended state, and allow the carrier element to carry the container when it is in the retracted state.
本发明的容器操作机构的一个实施例中,所述承载元件包括至少两个插齿,至少两个所述插齿均设置在所述壳体上并且相互平行设置。In one embodiment of the container operating mechanism of the present invention, the bearing element includes at least two pins, and at least two pins are both arranged on the housing and arranged parallel to each other.
本发明的容器操作机构的一个实施例中,所述容器码垛组件包括:In one embodiment of the container operating mechanism of the present invention, the container palletizing assembly includes:
第二壳体,所述第二壳体设置在所述第一壳体上或者所述运动组件上;a second housing, the second housing is arranged on the first housing or on the moving assembly;
第二吸盘,所述第二吸盘设置在所述第二壳体上并且受控于第二真空发生装置用于吸附或松开容器。The second suction cup is arranged on the second housing and is controlled by the second vacuum generating device for sucking or loosening the container.
本发明的容器操作机构的一个实施例中,所述容器码垛组件包括多个所述第二吸盘;In one embodiment of the container handling mechanism of the present invention, the container palletizing assembly includes a plurality of the second suction cups;
本发明的容器操作机构的一个实施例中,多个所述第二吸盘依次间隔设置。In one embodiment of the container operating mechanism of the present invention, a plurality of the second suction cups are sequentially arranged at intervals.
本发明的容器操作机构的一个实施例中,所述容器操作机构包括至少两个所述容器码垛组件,至少两个所述容器码垛组件平行设置。In one embodiment of the container operating mechanism of the present invention, the container operating mechanism includes at least two container palletizing assemblies, and at least two container palletizing assemblies are arranged in parallel.
本发明的容器操作机构的一个实施例中,所述容器操作机构还包括第一检测元件,所述第一检测元件被配置成用于检测所述第一目标位置或所述第二目标位置上的容器和目标容器两者的识别信息是否一致;In an embodiment of the container operating mechanism of the present invention, the container operating mechanism further includes a first detection element configured to detect the position of the first target position or the second target position Whether the identification information of the target container and the target container are consistent;
所述容器取放组件基于所述第一检测元件检测到的所述第一目标位置或所述第二目标位置上的容器和目标容器两者的识别信息一致时,取放容器。The container pick-and-place component picks and places the container when the identification information of the container at the first target position or the second target position detected by the first detection element is consistent with that of the target container.
第二方面,本发明还提供了一种容器码垛系统,其特征在于,所述容器码垛系统包括容器位置调整机构以及如上所述的容器操作机构。In a second aspect, the present invention also provides a container palletizing system, which is characterized in that the container palletizing system includes a container position adjustment mechanism and the above-mentioned container operating mechanism.
本发明的容器码垛系统的一个实施例中,所述容器码垛系统还包括托盘位置调整机构,所述托盘位置调整机构被配置为用于调整托盘至预设的第四目标位置,所述第三目标位置位于所述托盘上。In one embodiment of the container palletizing system of the present invention, the container palletizing system further includes a pallet position adjustment mechanism configured to adjust the pallet to a preset fourth target position, the A third target location is located on the pallet.
本发明的容器码垛系统的一个实施例中,所述容器码垛系统还包括第二检测元件,所述第二检测元件设置在所述托盘位置调整机构上,并且被配置成用于检测托盘是否满足码放容器的条件;In one embodiment of the container palletizing system of the present invention, the container palletizing system further includes a second detection element, the second detection element is arranged on the pallet position adjustment mechanism and is configured to detect the Whether the conditions for stacking containers are met;
所述容器码垛组件基于所述第二检测元件检测到的所述托盘满足码放容器的条件时,用于将容器码放在所述托盘上。The container palletizing component is used to stack containers on the pallet when the pallet meets the conditions for stacking containers detected by the second detection element.
本发明的容器码垛系统的一个实施例中,所述第二检测元件包括到位检测元件,所述到位检测元件被配置成用于检测所述托盘是否调整至所述第四目标位置;In an embodiment of the container palletizing system of the present invention, the second detection element includes an in-position detection element configured to detect whether the pallet is adjusted to the fourth target position;
所述容器码垛组件基于所述到位检测元件检测到的所述托盘调整至所述第四目标位置时,用于将容器码放在所述托盘上。The container palletizing assembly is used for stacking containers on the pallet when the pallet is adjusted to the fourth target position detected by the presence detection element.
本发明的容器码垛系统的一个实施例中,所述第二检测元件还包括托盘状态检测元件,所述托盘状态检测元件被配置成用于检测所述托盘上是否有异物;In an embodiment of the container palletizing system of the present invention, the second detection element further includes a tray state detection element configured to detect whether there is a foreign object on the tray;
所述容器码垛组件基于所述托盘状态检测元件检测到的托盘上没有异物时,用于将容器码放在所述托盘上。The container palletizing assembly is used to stack containers on the pallet when there is no foreign object on the pallet detected by the pallet state detecting element.
本发明的容器码垛系统的一个实施例中,所述托盘位置调整机构还包括报警单元,所述报警单元与所述第二检测元件通信连接,且被配置为当第二检测元件检测到托盘不满足码放容器的条件时发出预警信号。In one embodiment of the container palletizing system of the present invention, the pallet position adjustment mechanism further includes an alarm unit, which is connected in communication with the second detection element and is configured to An early warning signal is issued when the conditions for stacking containers are not met.
本发明的容器码垛系统的一个实施例中,所述容器位置调整机构包括:In one embodiment of the container palletizing system of the present invention, the container position adjustment mechanism includes:
缓存台;buffer table;
固定挡板,所述固定挡板固定设置在所述缓存台上;a fixed baffle, and the fixed baffle is fixedly arranged on the buffer table;
第一活动挡板,所述第一活动挡板被构造为受控于第一定位驱动机构以可升降的方式设置在所述缓存台上,且所述容器取放组件被配置为所述第一活动挡板位于低位时将容器放置在所述缓存台上;A first movable baffle, the first movable baffle is configured to be set on the buffer platform in a liftable manner controlled by a first positioning drive mechanism, and the container pick-and-place assembly is configured as the first movable baffle A movable baffle is placed in the lower position to place the container on the buffer table;
第二活动挡板,所述第二活动挡板被构造为受控于第二定位驱动机构以活动地方式设置在所述缓存台上,并且用于推动容器运动至与所述固定挡板相抵;A second movable baffle, the second movable baffle is configured to be controlled by a second positioning drive mechanism to be movably arranged on the buffer platform, and is used to push the container to move against the fixed baffle ;
第三活动挡板,所述第三活动挡板被构造为受控于第三定位驱动机构以活动的方式设置在所述缓存台上,并且用于推动容器运动至与位于高位的所述第一活动挡板相抵。The third movable baffle, the third movable baffle is configured to be controlled by a third positioning drive mechanism to be movably arranged on the buffer platform, and is used to push the container to move to the high position of the first movable baffle. A movable baffle offsets each other.
本发明的容器码垛系统的一个实施例中,所述缓存台还具有升降导向孔,所述第一活动挡板沿所述升降导向孔升降。In one embodiment of the container palletizing system of the present invention, the buffer platform further has a lifting guide hole, and the first movable baffle is lifted and lowered along the lifting guide hole.
本发明的容器码垛系统的一个实施例中,所述容器位置调整机构还包括组合平台,所述组合平台设置在所述缓存台上,并且被构造成用于码放容器尺寸小于预定尺寸的容器。In one embodiment of the container palletizing system of the present invention, the container position adjustment mechanism further includes a combination platform, the combination platform is arranged on the buffer table and is configured to stack containers whose size is smaller than a predetermined size .
本发明的容器码垛系统的一个实施例中,所述组合平台包括第二缓存覆板和缓存支架,所述第二缓存覆板位于所述缓存台的上方并且通过所述缓存支架固定设置在所述缓存台上。In one embodiment of the container palletizing system of the present invention, the combined platform includes a second buffer cover plate and a buffer bracket, and the second buffer cover plate is located above the buffer platform and fixedly arranged on the on the cache table.
本发明的容器码垛系统的一个实施例中,所述托盘位置调整机构包括左侧导向条、右侧导向条和端部止挡件;In one embodiment of the container palletizing system of the present invention, the pallet position adjustment mechanism includes a left guide strip, a right guide strip and an end stopper;
所述左侧导向条和所述右侧导向条被配置成用于导入受到外力的托盘,所述端部止挡件被配置成当托盘在外力作用下运动至第四目标位置时阻止所述托盘沿导入方向的运动。The left side guide strip and the right side guide strip are configured to guide the tray subjected to external force, and the end stopper is configured to stop the tray when the tray moves to the fourth target position under the action of external force. Movement of the pallet in the direction of infeed.
本发明的容器码垛系统的一个实施例中,所述容器码垛系统还包括安全防护机构,所述安全防护机构被构造成合围所述容器操作机构、所述容器位置调整机构和所述托盘位置调整机构,并且具有操作口和出入口;In one embodiment of the container palletizing system of the present invention, the container palletizing system further includes a safety protection mechanism, and the safety protection mechanism is configured to surround the container operation mechanism, the container position adjustment mechanism and the pallet The position adjustment mechanism has an operation port and an entrance and exit;
所述容器操作机构被配置为通过所述操作口伸出所述安全防护机构围挡的区域从所述第一目标位置上取出容器或者将容器(8)放入所述第一目标位置;The container operating mechanism is configured to take out the container from the first target position or put the container (8) into the first target position through the operating port protruding from the area enclosed by the safety protection mechanism;
所述出入口被构造为用于供所述托盘进出所述安全防护机构围挡的区域。The access port is configured for the tray to enter and exit the area enclosed by the safety protection mechanism.
本发明的容器码垛系统的一个实施例中,所述安全防护机构包括依次间隔设置的多个立柱,以及连接相邻两个所述立柱的遮挡件,其中,与所述第一目标位置所在位置处相邻的两个所述立柱之间未设置所述遮挡件以形成所述操作口。In one embodiment of the container palletizing system of the present invention, the safety protection mechanism includes a plurality of uprights arranged at intervals in sequence, and a shield connecting two adjacent uprights, wherein, the same as the first target position The blocking member is not provided between the two adjacent columns at positions to form the operation opening.
本发明的容器码垛系统的一个实施例中,所述第一目标位置位于载具上。In an embodiment of the container palletizing system of the present invention, the first target position is located on a carrier.
第三方面,本发明还提供一种容器码垛系统的控制方法,所述容器码垛系统为如上所述的容器码垛系统,其特征在于,所述控制方法包括以下步骤:In a third aspect, the present invention also provides a control method for a container palletizing system, the container palletizing system is the container palletizing system as described above, and it is characterized in that the control method includes the following steps:
步骤S1000,所述运动组件带动所述容器取放组件运动至所述第一目标位置,且所述容器取放组件取出所述第一目标位置上的容器;Step S1000, the moving component drives the container pick-and-place component to move to the first target position, and the container pick-and-place component takes out the container at the first target position;
步骤S2000、所述运动组件带动容器取放组件运动至所述容器位置调整机构上,且所述容器取放组件将容器放置在所述容器位置调整机构上;Step S2000, the moving component drives the container pick-and-place component to move to the container position adjustment mechanism, and the container pick-and-place component places the container on the container position adjustment mechanism;
步骤S3000、所述容器位置调整机构调整容器至预设的第二目标位置;Step S3000, the container position adjustment mechanism adjusts the container to a preset second target position;
步骤S4000、所述运动组件带动所述容器码垛组件运动至所述第二目标位置,且所述容器码垛组件取出所述第二目标位置上的容器;Step S4000, the moving component drives the container palletizing component to move to the second target position, and the container palletizing component takes out the container at the second target position;
步骤S5000、所述运动组件带动所述容器码垛组件运动至所述第三目标位置上,且所述容器码垛组件将容器码放在第三目标位置上。Step S5000, the moving component drives the container palletizing component to move to the third target position, and the container palletizing component stacks the container on the third target position.
本发明的控制方法的一个实施例中,所述第三目标位置位于托盘上;In an embodiment of the control method of the present invention, the third target position is located on the pallet;
在所述步骤S3000之后,所述控制方法还包括检测所述托盘是否满足码放容器条件的步骤。After the step S3000, the control method further includes the step of detecting whether the pallet satisfies the condition for stacking containers.
本发明的控制方法的一个实施例中,所述步骤S1000中,所述容器取放组件通过与所述第一目标位置上的容器的前端面结合以取出所述容器。In one embodiment of the control method of the present invention, in the step S1000, the container pick-and-place component combines with the front surface of the container at the first target position to take out the container.
本发明的控制方法的一个实施例中,所述步骤S4000中,所述容器码垛组件通过与所述第一目标位置上的容器的顶面结合以取出所述容器。In one embodiment of the control method of the present invention, in the step S4000, the container palletizing assembly combines with the top surface of the container at the first target position to take out the container.
本发明的控制方法的一个实施例中,检测所述托盘是否满足码放容器条件的检测方法包括:In one embodiment of the control method of the present invention, the detection method for detecting whether the pallet meets the conditions for stacking containers includes:
检测所述托盘是否调整至预设的第四目标位置;和/或detecting whether the tray is adjusted to a preset fourth target position; and/or
检测所述托盘上是否有异物。Check for foreign objects on the tray.
本发明的控制方法的一个实施例中,在所述步骤S1000中,还包括读取所述第一目标位置上容器的信息,所述信息包括容器的尺寸;In one embodiment of the control method of the present invention, in the step S1000, it further includes reading the information of the container at the first target position, the information including the size of the container;
当容器尺寸小于预定尺寸时,在步骤S3000中,所述容器码垛组件取出所述第二目标位置上的容器,并将容器排布在排布目标位置上;When the size of the container is smaller than the predetermined size, in step S3000, the container palletizing assembly takes out the container at the second target position, and arranges the container at the target position;
当所述排布目标位置的组合容器尺寸符合所述预定尺寸时,在步骤S4000中,所述容器码垛组件将所述排布目标位置的多个容器码放在所述第三目标位置。When the size of the combined container at the arrangement target position conforms to the predetermined size, in step S4000, the container stacking assembly puts a plurality of containers at the arrangement target position at the third target position.
本发明的容器操作机构的运动组件先带动容器取放组件运动至第一目标位置处,再由容器取放组件取出第一目标位置上的容器;然后,运动组件带动容器取放组件运动至容器位置调整机构处,并且将其放置在容器位置调整机构上;再由容器位置调整机构调整该容器的位置至预设的第二目标位置,然后运动组件带动容器码垛组件运动至第三目标位置处,最后容器码垛组件将该容器码放在第三目标位置上。The moving component of the container operating mechanism of the present invention first drives the container picking and placing component to move to the first target position, and then the container picking and placing component takes out the container at the first target position; then, the moving component drives the container picking and placing component to move to the container position adjustment mechanism, and place it on the container position adjustment mechanism; then adjust the position of the container to the preset second target position by the container position adjustment mechanism, and then the movement component drives the container palletizing component to move to the third target position At the last container stacking assembly, the container is stacked on the third target position.
由此可知,本发明的容器操作机构在容器取放组件取出容器之后,先利用容器位置调整机构将容器调整至预设的第二目标位置处,然后容器码垛组件才从第二目标位置上取出该容器码放在托盘上,将容器码垛组件与容器之间的结合位置限定在允许的偏差范围之内,从而能使容器码垛组件可以将容器的码放位置控制在预设的码放位置处,或者可以将容器的实际码放位置与预设的码放位置之间的偏差量控制在允许的偏差范围之内,避免了该容器与在先码放的容器之间和/或后续待码放的容器之间的位置干涉,保证了码放工作顺畅且有序的进行。It can be seen from this that, after the container handling mechanism of the present invention takes out the container by the container pick-and-place assembly, it first uses the container position adjustment mechanism to adjust the container to the preset second target position, and then the container palletizing assembly starts from the second target position. Take out the container and stack it on the pallet, and limit the joint position between the container palletizing component and the container within the allowable deviation range, so that the container palletizing component can control the stacking position of the container at the preset stacking position , or the deviation between the actual stacking position of the container and the preset stacking position can be controlled within the allowable deviation range, so as to avoid the The positional interference between them ensures the smooth and orderly progress of the stacking work.
另外,容器码垛系统上配置组合平台,将尺寸小于预定尺寸的容器暂时缓存在组合平台上,待组合后达到预定尺寸后再整体由容器码垛组件码放至第三目标位置上,与不考虑容器尺寸逐一码放容器相比,可以提高码垛效率。In addition, the container palletizing system is equipped with a combination platform, and the containers whose size is smaller than the predetermined size are temporarily buffered on the combination platform. Compared with stacking containers one by one according to the container size, the stacking efficiency can be improved.
还有,容器操作机构利用容器取放组件通过与容器的前端面结合取出载具上的容器,而又利用容器码垛组件通过与容器的顶面结合取出容器定位机构上的容器,既可以密集存放容器也可以密集码放容器,充分利用载具和托盘上的空间,提高载具或托盘的容器摆放能力。In addition, the container operating mechanism uses the container pick-and-place component to take out the container on the carrier by combining with the front surface of the container, and uses the container palletizing component to take out the container on the container positioning mechanism by combining with the top surface of the container, which can be densely packed. The storage containers can also be stacked densely, making full use of the space on the carrier and the pallet, and improving the container placement capacity of the carrier or pallet.
附图说明Description of drawings
被结合在说明书中并构成说明书的一部分的附图示出了本发明的实施例,并且连同其说明一起用于解释本发明的原理。The accompanying drawings, which are incorporated in and constitute a part of this specification, illustrate embodiments of the invention and together with the description serve to explain the principles of the invention.
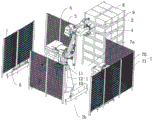
图1是本发明所提供的容器码垛系统的具体实施例的工作状态示意图;Fig. 1 is the working state schematic diagram of the specific embodiment of container palletizing system provided by the present invention;
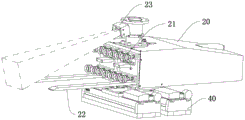
图2是容器取放组件和容器码垛组件的装配体的立体图;Fig. 2 is a perspective view of the assembly of the container pick-and-place assembly and the container palletizing assembly;
图3至图5分别是图2所示装配体的主视图、俯视图和侧视图;Fig. 3 to Fig. 5 are respectively the front view, top view and side view of the assembly shown in Fig. 2;
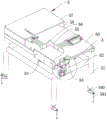
图6是容器位置调整机构的立体图;Fig. 6 is a perspective view of a container position adjustment mechanism;
图7是图6的A处局部放大图;Fig. 7 is a partial enlarged view of A in Fig. 6;
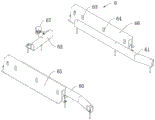
图8是托盘位置调整机构的立体图;Fig. 8 is a perspective view of the tray position adjustment mechanism;
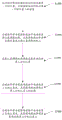
图9是本发明所提供的容器码垛系统的控制方法的主要步骤流程示意图;Fig. 9 is a schematic flow chart of the main steps of the control method of the container palletizing system provided by the present invention;
图10是本发明所提供的容器码垛系统的控制方法的详细步骤流程示意图。Fig. 10 is a schematic flowchart of the detailed steps of the control method of the container palletizing system provided by the present invention.
图1至图8中各组件名称和附图标记之间的一一对应关系如下:The one-to-one correspondence between the names of the components and the reference numerals in Fig. 1 to Fig. 8 is as follows:
1底座:10底板、11顶板、12立杆;1 Base: 10 bottom plates, 11 top plates, 12 vertical poles;
2容器取放组件:20第一壳体、21第一吸盘、22插齿、23第一检测元件;2 Container pick-and-place components: 20 the first shell, 21 the first suction cup, 22 the pinion, 23 the first detection element;
3运动组件;3 motion components;
4容器码垛组件:40第二壳体、41连接支架、42紧固件;4 Container palletizing components: 40 second shell, 41 connecting bracket, 42 fasteners;
5容器位置调整机构:50缓存覆板、51支腿、52横梁、53固定挡板、54第一活动挡板、55第二活动挡板、56第三活动挡板、57第二缓存覆板、58缓存支架、59导向板、5a升降导向孔、590地脚、591化学螺栓;5 Container position adjustment mechanism: 50 cache cover, 51 outrigger, 52 beam, 53 fixed baffle, 54 first movable baffle, 55 second movable baffle, 56 third movable baffle, 57 second cache cover , 58 cache bracket, 59 guide plate, 5a lifting guide hole, 590 foot, 591 chemical bolt;
6托盘位置调整机构:60左侧导向条、61右侧导向条、62端部止挡件、63到位检测元件、64托盘状态检测装置、65左侧安装支架、66右侧安装支架、67报警单元;6 Tray position adjustment mechanism: 60 left guide bar, 61 right guide bar, 62 end stopper, 63 in-position detection element, 64 pallet state detection device, 65 left mounting bracket, 66 right mounting bracket, 67 alarm unit;
7安全防护机构:70立柱、71遮挡件、7a操作口、7b出入口。7 Safety protection mechanism: 70 pillars, 71 blocking parts, 7a operation port, 7b entrance and exit.
8容器;8 containers;
9载具。9 vehicles.
具体实施方式Detailed ways
现在将参照附图来详细描述本发明的各种示例性实施例。应注意到:除非另外具体说明,否则在这些实施例中阐述的部件和步骤的相对布置、数字表达式和数值不限制本发明的范围。Various exemplary embodiments of the present invention will now be described in detail with reference to the accompanying drawings. It should be noted that the relative arrangements of components and steps, numerical expressions and numerical values set forth in these embodiments do not limit the scope of the present invention unless specifically stated otherwise.
以下对至少一个示例性实施例的描述实际上仅仅是说明性的,决不作为对本发明及其应用或使用的任何限制。The following description of at least one exemplary embodiment is merely illustrative in nature and in no way taken as limiting the invention, its application or uses.
对于相关领域普通技术人员已知的技术、方法和设备可能不作详细讨论,但在适当情况下,所述技术、方法和设备应当被视为说明书的一部分。Techniques, methods and devices known to those of ordinary skill in the relevant art may not be discussed in detail, but where appropriate, such techniques, methods and devices should be considered part of the description.
在这里示出和讨论的所有例子中,任何具体值应被解释为仅仅是示例性的,而不是作为限制。因此,示例性实施例的其它例子可以具有不同的值。In all examples shown and discussed herein, any specific values should be construed as exemplary only, and not as limitations. Therefore, other instances of the exemplary embodiment may have different values.
应注意到:相似的标号和字母在下面的附图中表示类似项,因此,一旦某一项在一个附图中被定义,则在随后的附图中不需要对其进行进一步讨论。It should be noted that like numerals and letters denote like items in the following figures, therefore, once an item is defined in one figure, it does not require further discussion in subsequent figures.
为了提高仓储系统的上下料效率,第一方面本发明提供了一种容器码垛系统,该容器码垛系统用于控制器的要求从仓库的多个不同载具上取放容器,并且将取出的容器码放到托盘上,该托盘可以自动或人工作用下在仓库的不同目标区域之间移动,以运输容器。载具被构造为用于存放或承载容器,载具包括货架(如隔板货架、货箱货架)、托盘支架、笼车、托板支架、货车等。每个载具包括多个存储位,每个存储位用于容纳容器。为了便于理解,下文中将使用序数词“第一”、“第二”、“第三”、“第四”等来区分两个不同的目标位置,可以理解上述序数词对本发明的保护范围不产生限定作用。In order to improve the loading and unloading efficiency of the storage system, the first aspect of the present invention provides a container palletizing system, the container palletizing system is used for the controller to pick and place containers from multiple different carriers in the warehouse, and will take out Containers are stacked onto pallets that can be moved automatically or manually between different target areas of the warehouse to transport the containers. The carrier is configured to store or carry containers, and the carrier includes a shelf (such as a partition shelf, a container shelf), a pallet support, a cage car, a pallet support, a truck, and the like. Each carrier includes a plurality of storage locations, each storage location for receiving a container. In order to facilitate understanding, the ordinal numbers "first", "second", "third", "fourth" and so on will be used hereinafter to distinguish two different target positions. have a limiting effect.
另外,需要说明的是,从存放功能区分,本发明中的容器包括通用容器和专用容器,其中,通用容器是指可以存放任何货物的容器,比如收纳箱、整理箱等,专用容器是指专门用于放置某一种或某一类货物的容器,比如鞋盒、生鲜箱、水桶等。从材质区分,本发明的纸箱、玻璃瓶、塑料箱、金属箱、皮箱等。In addition, it should be noted that, in terms of storage functions, the containers in the present invention include general-purpose containers and special-purpose containers, wherein, general-purpose containers refer to containers that can store any goods, such as storage boxes, sorting boxes, etc., and special-purpose containers refer to special-purpose containers. Containers for placing a certain type or type of goods, such as shoe boxes, fresh boxes, buckets, etc. Distinguished from materials, cartons, glass bottles, plastic boxes, metal boxes, leather boxes, etc. of the present invention.
本发明提供一种容器操作机构及包括该容器操作机构的容器码垛系统,为了便于理解和保持文本简洁,下面本文将结合图1至9,以容器码垛系统的一个实施例为例一并说明容器操作机构和容器码垛系统的具体结构及工作原理,不再对容器操作机构单独进行说明。The present invention provides a container operating mechanism and a container palletizing system including the container operating mechanism. In order to facilitate understanding and keep the text concise, the following article will take an embodiment of the container palletizing system as an example in combination with FIGS. 1 to 9 Explain the specific structure and working principle of the container operating mechanism and the container palletizing system, and will not explain the container operating mechanism separately.
参见图1,本申请的容器码垛系统包括容器操作机构和容器位置调整机构。Referring to Fig. 1, the container palletizing system of the present application includes a container operating mechanism and a container position adjusting mechanism.
其中,容器操作机构包括底座1、容器取放组件2、运动组件3和容器码垛组件4。Wherein, the container operating mechanism includes a
其中,容器取放组件2被构造成用于取出位于第一目标位置上的容器8,且将取出的容器8放置在容器位置调整机构上,容器位置调整机构被配置为用于将容器8调整到预设的第二目标位置。容器码垛组件4被构造成用于取出第二目标位置上的容器8,且将该容器8码放在第三目标位置;运动组件3设置在底座1上,且被配置带动容器取放组件2和容器码垛组件4运动。Wherein, the container pick-and-
需要说明的是,第一目标位置和第三目标位置可以为同一个目标位置,也可以为不同的目标位置,第一目标位置和第二目标位置可以位于托盘、载具、容器缓存架等仓库系统中常用的部件。It should be noted that the first target position and the third target position may be the same target position or different target positions, and the first target position and the second target position may be located in warehouses such as pallets, carriers, container buffer racks, etc. Commonly used components in the system.
为了便于理解,本实施例中容器操作机构主要在载具、容器位置调整机构和托盘三者之间取送容器,第一目标位置为载具上的存储容器的存储位,第三目标位置则是指托盘上码放容器的码放位。下面结合该实施例详细说明容器操作机构在上述三个部件之间的码垛容器的工作原理。For easy understanding, in this embodiment, the container operating mechanism mainly picks and delivers containers between the carrier, the container position adjustment mechanism and the tray. The first target position is the storage position of the storage container on the carrier, and the third target position is It refers to the stacking position where the container is stacked on the pallet. The working principle of the stacking container between the above three components of the container operating mechanism will be described in detail below in conjunction with this embodiment.
另外,需要说明的是,本文中描述容器码垛系统时所使用的方位词“前”、“顶”和“底”是以容器8放置在载具上时为基准设置的,载具的容器上面向用户侧或者载具的容器取放口的开口朝向为“前”,容器上靠近地面侧为“底”,远离地面侧为“顶”。In addition, it should be noted that the orientation words "front", "top" and "bottom" used in describing the container palletizing system herein are based on when the container 8 is placed on the carrier. The opening direction of the container access opening facing the user side or the vehicle is "front", the side of the container close to the ground is "bottom", and the side away from the ground is "top".
详细地,参见图1,底座1包括底板10、顶板11和立杆12,其中,底板10和顶板11通过立杆12固定连接,并且在底板10和顶板11之间设置了与立杆12固定连接的多个加强肋板。底座1放置在仓库的地面上或者通过螺钉固定连接在地面上。In detail, referring to FIG. 1 , the
运动组件3设置在顶板11上,具体地,本实施例中,运动组件3具体地为机械臂,该机械臂可以根据预定程序执行移动、旋转、俯仰等各种动作,继而带动容器取放组件2在不同的目标位置之间运动。当然,机械臂也可以根据用户或外部设备发出的控制指令执行相应的移动、旋转、俯仰等各种动作。可以理解,在满足驱动容器取放组件2在不同的目标位置之间运动功能基础上,该运动组件3并不仅限于机械臂。The
还需要说明的是,本发明的容器操作机构还可以包括控制器(图中未示出),该控制器被配置成用于控制取放容器组件2、运动组件3、容器码垛组件4等各个功能组件执行相应的动作。在一些实施例中,容器操作机构可以配置独立的专用控制器。在另一些实施例中,该容器操作机构各个功能组件可有由用户或者仓储系统的控制器控制,即,由容器操作机构的外部控制器控制。It should also be noted that the container operating mechanism of the present invention may also include a controller (not shown in the figure), which is configured to control the pick-and-
结合图2至图5,容器取放组件2包括第一壳体20、第一吸盘21和第一真空发生装置(图中未示出)。其中,第一壳体20设置在运动组件3上。具体地,第一壳体20固定连接在机械臂的末轴端,第一吸盘21设置在第一壳体20上,并且第一吸盘21通过气体管路和第一真空发生装置连接。Referring to FIGS. 2 to 5 , the container pick-and-
当启动第一真空发生装置时,气体管路通气,第一吸盘21内部的空气被抽走,在第一吸盘21内形成了负压的真空状态。此时,第一吸盘21内部的空气压力低于第一吸盘21外部的大气压力,容器8在外部负压的作用下被吸起。第一吸盘21内部的真空度越高,第一吸盘21与容器8之间贴的越紧。真空吸附具有清洁,吸附平稳,可靠,不损坏容器8表面的优点。When the first vacuum generating device is started, the gas pipeline is ventilated, the air inside the
进一步地,本实施例中,本发明的容器取放组件2与容器8的前端面结合以从第一目标位置上取出容器8。相邻容器之间无需预留供取出组件插入的空间,可以在载具上密集存放容器,充分利用载具上的空间,提高载具的容器摆放能力。Further, in this embodiment, the container pick-and-
另外,本实施例中,本发明的容器取放组件通过吸取方式取放容器。In addition, in this embodiment, the container pick-and-place assembly of the present invention picks and places the container by suction.
根据本发明的另一些实施例,容器取放组件也可以通过推动、夹取、取出、钩取、抱起、抬升方式中的至少一种取放容器。According to some other embodiments of the present invention, the container pick-and-place assembly can also pick and place the container by at least one of pushing, clamping, taking out, hooking, picking up, and lifting.
进一步地,为了提高容器取放组件2取放容器8的稳定性和可靠性,容器取放组件2包括若干个第一吸盘21,若干个第一吸盘21被分成至少两排,并且至少两排第一吸盘21彼此相互平行设置。Further, in order to improve the stability and reliability of the container pick-and-
具体地,参见图2,本实施例中,容器取放组件2包括14个第一吸盘21,并且这14个第一吸盘21被均分成平行设置的两排,每排的7个第一吸盘21依次间隔设置。Specifically, referring to Fig. 2, in the present embodiment, the container pick-and-
如此设置,容器取放组件2和容器8之间形成多个吸附的点,吸附力较大,能保证取出容器8的稳定性和可靠性。可以理解,本领域技术人员可以根据实际需要,自行选择第一吸盘21的数量以及排布方式。With such arrangement, multiple adsorption points are formed between the container pick-and-
继续参见图2,本实施例中,容器取放组件2还包括承载元件,承载元件设置在第一壳体20上并且位于第一吸盘21的下方,承载元件被构造成用于承载容器8。Continuing to refer to FIG. 2 , in this embodiment, the container pick-and-
进一步地,容器取放组件2还包括伸缩驱动组件,伸缩驱动组件被配置为驱动第一吸盘21相对于第一壳体20沿取放容器8的方向伸缩运动,并且第一吸盘21被构造为位于伸出状态时超出承载元件以吸附容器8、位于缩回状态时使承载元件承载容器8。Further, the container pick-and-
初始状态下第一吸盘21位于缩回位置,即靠近第一壳体20位置,需要取出容器8时,伸缩驱动组件驱动第一吸盘21伸出直至其超过承载元件并且与容器8接触,启动第一真空发生装置,第一吸盘21吸附容器8;控制伸缩驱动组件驱动第一吸盘21缩回至初始位置,然后控制器关闭第一真空发生装置,第一吸盘21的吸附力消失,容器8因自重落在承载元件上;或者是第一吸盘21吸附容器的同时再由承载元件承载容器。In the initial state, the
可以理解,与单纯依赖第一吸盘21吸附容器8相比,该容器取放组件2设置承载元件,一方面可以避免第一真空发生装置意外失效时第一吸盘21失去吸附力,造成容器8跌落的风险,提高了取出容器8的可靠性。It can be understood that, compared with simply relying on the
另一方面,容器取放组件2取出容器8并返回至初始位置后,即可关闭第一真空发生装置,运输容器8过程中仅由承载元件来承载容器8。可以理解,与运送容器8过程中第一吸盘21持续吸附容器8的方式相比,这种运送方式可以减小第一真空发生装置的工作时长,节约能源。On the other hand, after the container pick-and-
详细地,伸缩驱动组件可以包括液压缸、电缸或气缸,其缸体固定在第一壳体20内,其活塞杆伸出至第一壳体20外并且连接第一吸盘21,通过驱动活塞杆由缸体伸出或缩回至缸体即可实现第一吸盘21相对于第一壳体20的沿取放容器8的方向伸缩运动。In detail, the telescopic driving assembly may include a hydraulic cylinder, an electric cylinder or an air cylinder, the cylinder body of which is fixed in the
当然,在另一些实施例中,该伸缩驱动组件包括滚珠丝杠螺母机构和电机,该滚珠丝杠螺母机构的丝杠通过轴承可转动的连接在第一壳体20上并由电机驱动转动,其螺母块位于第一壳体20外并且固定连接第一吸盘21,控制电机正反转即可实现第一吸盘21由第一壳体20伸出或者第一吸盘21缩回至第一壳体20。Of course, in some other embodiments, the telescopic drive assembly includes a ball screw nut mechanism and a motor, and the lead screw of the ball screw nut mechanism is rotatably connected to the
另外,伸缩驱动组件还可以是齿轮齿条传动、链传动、皮带传动等方式驱动,在此不再一一列举。In addition, the telescopic drive assembly can also be driven by rack and pinion drive, chain drive, belt drive, etc., which will not be listed here.
继续参见图2,本实施例中,承载元件包括固定连接在第一壳体20上的两个插齿22,两个插齿22间隔平行设置在水平面内。当然,插齿22数量并不仅限于两个,插齿22的数量可以为大于2的整数个,这些插齿22之间依次间隔平行设置在水平面上即可。Continuing to refer to FIG. 2 , in this embodiment, the bearing element includes two
当然,承载元件的结构并不仅限于插齿22,在另一些实施中容器取放组件2也可以用整块板材作为承载元件,只要能满足承载容器8功能即可。Certainly, the structure of the load-bearing element is not limited to the
当第一目标位置上存放有容器8时,运动组件3即可带动容器取放组件2运动至第一目标位置并且取出第一目标位置上的容器8,但是第一目标位置上可能存放着包装各种不同类型产品的容器8,而如何从繁多的容器8中找到需要取出的目标容器,是容器取放组件2从第一目标位置上取出容器8的条件。When a container 8 is stored on the first target position, the moving
其中,目标容器是指用户或仓储系统的上一级控制单元需要容器操作机构取出的容器,目标容器的识别信息包括产品名称、产地、供应商等相关信息,识别信息可以以条形码或二维码的形式设置在容器上。Among them, the target container refers to the container that needs to be taken out by the user or the upper-level control unit of the storage system. The identification information of the target container includes product name, place of origin, supplier and other relevant information. The form is set on the container.
为此,继续参见图2,容器操作机构包括第一检测元件23,第一检测元件23被配置成用于检测第一目标位置上的容器8和目标容器两者的识别信息是否一致。To this end, referring to FIG. 2 , the container operating mechanism includes a
当第一目标位置上的容器8和目标容器两者的识别信息一致时,运动组件3带动容器取放组件2从当前位置运动至第一目标位置处,再由容器取放组件2取出第一目标位置上的容器8;否则,运动组件3带动容器取放组件2移动至下一个第一目标位置,并再次控制第一检测元件23检测该第一目标位置上的容器8和目标容器两者的识别信息是否一致,直至找到与目标容器的识别信息一致的容器,或者是发出预警信号,提醒用户或控制器容器取出失败。需要说明的是,预警信号可以是声音信号、光信号或文字信号,也可以是声音信号、光信号和文字信号三者中任意两者的组合。When the identification information of the container 8 on the first target position is consistent with that of the target container, the moving
具体地,该第一检测元件23还包括容器识别元件和判断单元。其中,容器识别元件设置在容器取放组件2上,并且被配置成用于识别容器8的识别信息;判断单元和容器识别元件通信连接,并且被配置成用于判断当前容器识别元件识别到的识别信息与容器取放组件2需要取出的目标容器的识别码是否一致。Specifically, the
当容器识别元件识别到当前容器8的识别信息与容器取放组件2将要取出的目标容器的识别码一致时,容器取放组件2取出该容器8。When the container identification component recognizes that the identification information of the current container 8 is consistent with the identification code of the target container to be taken out by the container pick-and-
需要说明的是,本实施例中第一检测元件23设置在容器取放组件2上,在满足识别容器8的识别信息功能的基础上,第一检测元件23也可以设置在容器码垛组件4或者运动组件3上,本领域技术人员基于容器操作机构的空间位置选择适宜的位置设置即可。It should be noted that, in this embodiment, the
结合图2至图5,容器码垛组件4包括第二壳体40和第二吸盘(图中未示出);其中,第二壳体40固定设置在第一壳体20的底部,第二吸盘固定设置在第二壳体40的底面并且与第二壳体40的腔室连通,第二壳体40上还开设有气体管路,第二真空发生装置通过气体管路与第二壳体40的腔室连通。2 to 5, the
当然,容器码垛组件4也可以设置在运动组件3上,比如在运动组件3上设置一个向载具9方向延伸的悬臂支架,容器码垛组件4的第二壳体40固定设置在该悬臂支架上,只要保证第二吸盘的吸附口可以朝向容器8的顶面即可。Of course, the
启动第二真空发生装置,第二壳体40的腔室内形成负压,在内外压差的作用下,第二吸盘吸附住容器。When the second vacuum generating device is activated, a negative pressure is formed in the chamber of the
容器码垛组件4包括若干个第二吸盘,若干个第二吸盘被分成至少两排,并且至少两排第二吸盘彼此相互平行设置。The
如此设置,容器码垛组件4和容器8之间形成多个吸附的点,吸附力较大,能保证取出容器8的稳定性和可靠性。可以理解,本领域技术人员可以根据实际需要,自行选择第二吸盘的数量以及排布方式。With such arrangement, a plurality of adsorption points are formed between the
另外,本实施例中,本发明的容器码垛组件4通过吸取方式取出或码放容器。In addition, in this embodiment, the
根据本发明的另一些实施例,容器码垛组件4也可以通过钩取方式中取出或码放容器。钩取方式是指容器码垛组件4上可以设置吊钩,容器的顶部上以可拆卸的方式设置吊环,容器码垛组件4要取出容器前,人工或机器人将该吊环连接在容器上,容器码垛组件4码放好容器后,再由人工或机器人将该吊环从容器上拆除。According to other embodiments of the present invention, the
继续参见图1,本实施例中,容器操作机构包括两个容器码垛组件4,这两个容器码垛组件4平行设置,以便提高容器操作机构操作容器的稳定性。Continuing to refer to FIG. 1 , in this embodiment, the container operating mechanism includes two
详细地,容器操作机构包括连接支架41,连接支架41通过紧固件42固定设置在容器取放组件2的第一壳体20的底面上,两个容器码垛组件4固定设置在该连接支架41上。In detail, the container operating mechanism includes a connecting
需要说明的是,在另一些实施例中,容器操作机构可以包括一个容器码垛组件4或者是三个或三个以上的容器码垛组件4,本领域技术人员基于容器操作机构的排布空间及实际所需吸附力大小等因素确定容器码垛组件4的数量即可。It should be noted that, in some other embodiments, the container operating mechanism may include one
容器取放组件2从载具9的第一目标位置通过容器8的前端面与容器结合并吸附该容器8,然后运动组件3带动容器取放组件2运动至容器位置调整机构5处,容器取放组件2将容器8放置在容器位置调整机构5上,由容器位置调整机构5调整容器至第二目标位置上,需要说明的是,第二目标位置是运动组件3带动容器码垛组件4运动至取出容器的目标位置,第二目标位置预设在容器码垛系统的控制系统内,该控制系统将第二目标位置的位置信息(坐标值)发送给运动组件3,运动组件3将带动容器码垛组件4运动至第二目标位置,容器也位于第二目标位置时,限定了容器码垛组件和容器之间的相对位置。The container pick-and-
本发明的容器码垛系统在容器取放组件取出容器之后,先利用容器位置调整机构将容器调整至预设的第二目标位置处,然后容器码垛组件才从第二目标位置上取出该容器码放在托盘上,将容器码垛组件与容器之间的结合位置限定在允许的偏差范围之内,从而能使容器码垛组件可以将容器的码放位置控制在预设的码放位置处,或者可以将容器的实际码放位置与预设的码放位置之间的偏差量控制在允许的偏差范围之内,避免了该容器与在先码放的容器之间和/或后续待码放的容器之间的位置干涉,保证了码放工作顺畅且有序的进行。In the container palletizing system of the present invention, after the container pick-and-place component takes out the container, the container position adjustment mechanism is used to adjust the container to the preset second target position, and then the container palletizing component takes out the container from the second target position Stacked on the pallet, the joint position between the container palletizing component and the container is limited within the allowable deviation range, so that the container palletizing component can control the stacking position of the container at the preset stacking position, or it can Control the deviation between the actual stacking position of the container and the preset stacking position within the allowable deviation range, avoiding the position between the container and the previously stacked container and/or the subsequent container to be stacked Interference ensures the smooth and orderly progress of the stacking work.
进一步地,容器码垛组件4通过与容器8的顶面结合取出容器8,以将容器密集码放在托盘上,充分利用托盘上的空间,提高托盘的通气摆放能力。Furthermore, the
运动组件3带动容器码垛组件4运动至托盘上,再由容器码垛组件5将该容器8码放在托盘的第三目标位置上。The moving
容器操作机构将载具9上的容器码放在托盘上,码放是指将多个容器先相互紧挨着摆放在托盘的盘面上,当托盘的盘面摆放满后,再将后续搬运过来的容器8摆放在第一层容器8的上方,如此将容器8叠加摆放至达到允许的最大摆放高度,最后由人工或搬运机器人将托盘运送至仓库中指定的目标区域即可。The container operating mechanism stacks the containers on the carrier 9 on the pallet. Stacking refers to placing multiple containers next to each other on the tray surface. When the tray surface is full, the subsequent transportation is carried over. Containers 8 are placed above the first layer of containers 8, so that the containers 8 are superimposed to reach the maximum allowable placement height, and finally the pallets are transported to the designated target area in the warehouse by manual or handling robots.
需要说明的是,本实施例的容器码垛系统中第二目标位置是预先设定的,以便补偿容器操作机构在不同目标区域之间运动时产生的位置偏差。It should be noted that, in the container palletizing system of this embodiment, the second target position is preset, so as to compensate the position deviation generated when the container operating mechanism moves between different target areas.
参考图6,容器位置调整机构5包括缓存台、固定挡板53、第一活动挡板54、第二活动挡板55和第三活动挡板56;其中,固定挡板53固定在缓存台上,第一活动挡板54受控于第一定位驱动机构以可升降的方式设置在缓存台上,并且被构造为位于低位时,容器取放组件2可以将容器推送至缓存台上;第二活动挡板55受控于第二定位驱动机构以活动地方式设置在缓存台上,并且被构造成用于推动容器至与固定挡板53相抵;第三活动挡板56受控于第三定位驱动机构以活动的方式设置在缓存台上,并且被构造成用于推动容器至与位于高位的第一活动挡板54相抵。With reference to Fig. 6, the container
详细地,本实施例中缓存台至少包括第一缓存覆板50和用于将第一缓存覆板50支撑在地面上的多个支腿51。In detail, the buffer platform in this embodiment at least includes a first
为了保证缓存台的稳定性,本实施例中,缓存台还包括与支腿51数量相匹配的地脚590和化学螺栓591;地脚590固定在支腿51的底面,化学螺栓591固定设置在地脚590上并且固定在地面上。In order to ensure the stability of the buffer platform, in the present embodiment, the buffer platform also includes
参考图7,容器位置调整机构5上还开设有升降导向孔5a,第一活动挡板54受控于第一定位驱动机构可沿升降导向孔5a升降。Referring to Fig. 7, the container
容器位置调整机构5包括导向板59,第一缓存覆板50上的边缘开设有导向槽,导向板59通过紧固件、焊接或粘接等方式固定设置在第一缓存覆板50上并且和导向槽围合形成升降导向孔5a。The container
第一定位驱动机构包括第一气缸,第一气缸的缸体固定设置在横梁52上并且与外部高压气源连通,横梁52用于固定连接相邻的两个支腿51,第一活动挡板54固定设置在第一气缸活塞杆的伸出端。The first positioning drive mechanism includes a first air cylinder, the cylinder body of the first air cylinder is fixedly arranged on the
第二定位驱动机构包括第二气缸,第二气缸的缸体固定设置在第一缓存覆板50上并且与外部高压气源连通,第二活动挡板55固定设置在第二气缸的活塞杆的伸出端。The second positioning drive mechanism includes a second cylinder, the cylinder body of the second cylinder is fixedly arranged on the first
第三定位驱动机构包括第三气缸,第三气缸的缸体固定设置在第一缓存覆板50上并且与外部高压气源连通,第三活动挡板56固定设置在第三气缸的活塞杆的伸出端。The third positioning drive mechanism includes a third cylinder, the cylinder body of the third cylinder is fixedly arranged on the first
容器位置调整机构5还包括气缸控制箱,该气缸控制箱被构造成用于控制第一气缸、第二气缸和第三气缸三者活塞杆的伸缩时机。The container
详细地,首先气缸控制器控制第一活动挡板54位于低位,即位于低位时第一活动挡板54位于第一缓存覆板50的板面下方,容器取放组件2将容器推送到第一缓存覆板50上,然后控制第一活动挡板54上升至高位,再控制第二活动挡板55推动容器8至容器8与固定挡板53相抵,控制第三活动挡板56推动容器8至容器8与第一活动挡板54相抵即可,至此将容器定位至缓存目标位置,然后运动组件驱动容器码垛组件4运动至定位好的容器8的上方,继续驱动容器码垛组件4下降至第二吸盘吸附在容器8的顶面上,运动组件继续驱动容器码垛组件4移动至托盘上的第二目标位置,关闭第二真空发生装置,第二吸盘吸附消失,容器8落到托盘上,如此循环操作直至托盘上码放的容器8达到允许搬运的高度或者数量。In detail, firstly, the cylinder controller controls the first movable baffle 54 to be in the low position, that is, when the first movable baffle 54 is located in the low position, the first movable baffle 54 is located below the surface of the first buffer cover plate 50, and the container pick-and-place assembly 2 pushes the container to the first buffer cover plate 50, then control the first movable baffle 54 to rise to a high position, then control the second movable baffle 55 to push the container 8 to the fixed baffle 53, and control the third movable baffle 56 to push the container 8 to It is enough for the container 8 to be against the first movable baffle plate 54, so far the container is positioned to the buffering target position, and then the moving assembly drives the container stacking assembly 4 to move to the top of the positioned container 8, and continues to drive the container stacking assembly 4 to descend to The second suction cup is adsorbed on the top surface of the container 8, the motion component continues to drive the container palletizing assembly 4 to move to the second target position on the pallet, the second vacuum generating device is turned off, the second suction cup adsorption disappears, and the container 8 falls onto the pallet , and operate in such a cycle until the container 8 stacked on the pallet reaches the height or quantity allowed to be transported.
同样,为了防止托盘在外力作用运动至超出预设的第四目标位置,继续参见图1,本实施例中,本申请的容器码垛系统还包括托盘位置调整机构6,托盘位置调整机构6被配置为用于调整托盘至预设的第四目标位置。Similarly, in order to prevent the pallet from moving beyond the preset fourth target position under the action of external force, continue to refer to FIG. Configured for adjusting the tray to a preset fourth target position.
限定托盘、载具9、容器位置调整机构三者之间的相对位置,以便容器操作机构能根据预设的路径快速准确在托盘上码放容器8。其中,第四目标位置是预先设定的,以便补偿容器操作机构在不同目标区域之间运动时产生的位置偏差。The relative positions among the tray, the carrier 9 and the container position adjustment mechanism are limited, so that the container operating mechanism can quickly and accurately stack the containers 8 on the tray according to the preset path. Wherein, the fourth target position is preset, so as to compensate the position deviation generated when the container operating mechanism moves between different target areas.
需要说明的是,一般地,托盘为长方体结构。It should be noted that, generally, the tray has a cuboid structure.
参见图8,托盘位置调整机构6包括左侧导向条60、右侧导向条61和端部止挡件62;其中,左侧导向条60和右侧导向条61被配置成用于导入受到外力的托盘,端部止挡件62被配置成当托盘到达预设的第四目标位置时阻止其沿导入方向的继续运动。Referring to Fig. 8, the tray
详细地,左侧导向条60和右侧导向条61均包括截面形状为方形的侧部导向管,以及用于将侧部导向管固定在地面上的化学螺栓。In detail, both the
端部止挡件62包括截面形状为方形的端部导向管、固定设置端部导向管的安装支架,以及将安装支架固定在地面上的化学螺栓。The
侧部导向管开设有贯穿孔,该贯穿孔被构造成用于供化学螺栓的螺杆贯穿。并且侧部导向管开设有用于供用户的手或外六角扳手等工具伸入后将螺母拧紧在螺杆上的操作口。The side guide pipe is provided with a through hole configured to allow the screw rod of the chemical bolt to pass through. And the side guide tube is provided with an operation port for the user's hands or tools such as an external hexagonal wrench to stretch in and tighten the nut on the screw rod.
更为详细地,该左侧导向条60和右侧导向条61向外侧倾斜形成导入口。以方便将托盘导入。In more detail, the
本实施例中,托盘位置调整机构6包括到位检测元件63,该到位检测元件63设置在左侧导向条60和/或右侧导向条61上,并且被配置成用于检测托盘是否调整至第四目标位置。In this embodiment, the tray
详细地,本实施例中,到位检测元件63包括相匹配的信号发射部件和信号接收部件,所述信号接收部件被构造为收到所述信号发射部件发射的信号时被触发。该到位检测元件63可以为光电对射传感器。In detail, in this embodiment, the
托盘位置调整机构6还包括左侧安装支架65和右侧安装支架66,左侧安装支架65上设置有到位检测元件63的信号发射部件,右侧安装支架66上设置有到位检测元件63的信号接收部件。The tray
本实施例中,左侧安装支架65和右侧安装支架66均为折弯成型的钣金结构,左侧安装支架65和右侧安装支架66均具有安装槽,到位检测元件63的对应部件安装在该安装槽内,并且由其槽口向水平方向折弯形成两个连接板,连接板通过化学螺栓固定在地面上,左侧安装支架65和右侧安装支架66的相对位置开设有供到位检测信号贯穿的信号贯穿孔。In this embodiment, both the left
在另一些实施例中,该到位检测元件63可以为接近开关,该接近开关被配置成当托盘到达第四目标位置后被触发。In other embodiments, the
进一步地,该托盘位置调整机构6还包括托盘状态检测元件64,托盘状态检测元件64被构造成用于检测托盘上是否有异物,容器码垛组件4基于托盘状态检测元件64检测到的托盘上没有异物时,将容器码放在托盘上。Further, the tray
在一些实施例中,托盘状态检测元件64包括相匹配的信号发射部件和信号接收部件,所述信号接收部件被构造为收到所述信号发射部件发射的信号时被触发。该托盘状态检测元件64可以为光电对射传感器。In some embodiments, the tray
继续参见图8,本实施例中,托盘位置调整机构6还包括报警单元67,该报警单元67与到位检测元件63和/或托盘状态检测元件64通信连接,且被配置为当第二检测元件检测到托盘不满足码放容器8的条件时发出预警信号,以提醒控制室内控制人员托盘的实际状态。Continuing to refer to FIG. 8 , in this embodiment, the tray
详细地,该报警单元67为信号灯,信号灯被配置成采用不同颜色的信号灯来输出不同的检测结果。In detail, the
比如当托盘被定位成功时,信号灯显示绿色,否则显示红色,当托盘上有异物时显示蓝色,否则显示白色等。本领域基于实际应用场景来选取合适的颜色即可。For example, when the tray is positioned successfully, the signal light is green, otherwise it is red, when there is a foreign object on the tray it is blue, otherwise it is white, etc. In this field, the appropriate color can be selected based on the actual application scene.
在另一些实施例中,该报警单元67可以为语音和/或文字显示装置。In other embodiments, the
为了提高码垛效率,本实施例中针对不同尺寸的容器采用不同的码垛方法。详细地,当容器的尺寸接近预设的容器尺寸时,容器位置调整机构5定位该容器后,容器码垛组件4取出该容器,然后将容器码放在托盘上。In order to improve the palletizing efficiency, different palletizing methods are adopted for containers of different sizes in this embodiment. In detail, when the size of the container is close to the preset container size, after the container
当容器的尺寸小于预设的容器尺寸时,容器取放组件2将该容器放置在容器位置调整机构5的缓存台上后,容器位置调整机构5定位该容器,然后容器码垛组件4通过与该容器的顶面结合后取出该容器并且将其码放在组合平台上,重复上述操作将另一个容器也码放在组合平台上,直至达到码放预定尺寸。当组合平台上摆放的多个容器8的整体尺寸达到预定尺寸时,容器码垛组件4一次将这些容器8吸附后由运动组件3运送至托盘处,再关闭容器码垛组件4的第二真空发生装置将这些小尺寸的容器8码放在托盘上,实现单次搬运多个容器的目的。When the size of the container is smaller than the preset container size, after the container pick-and-
详细地,组合平台设置在缓存台上,并且被构造成用于码放至少两个容器尺寸小于预定尺寸的容器。In detail, the combination platform is arranged on the buffer table, and is configured to stack at least two containers whose size is smaller than a predetermined size.
参考图6,组合平台包括位于缓存台上方的第二缓存覆板57以及连接第二缓存覆板57和缓存台的缓存支架58。Referring to FIG. 6 , the combination platform includes a second
需要说明的是,容器8的尺寸大小包含在容器8的识别信息内,如前所述,容器操作机构可以通过第一检测元件23获取容器的识别信息。It should be noted that the size of the container 8 is included in the identification information of the container 8 , as mentioned above, the container operating mechanism can obtain the identification information of the container through the
继续参见图1,容器码垛系统还包括安全防护机构7;其中,容器位置调整机构5被配置成用于暂时放置容器操作机构从载具9上取出回来的容器8,或者是容器操作机构从托盘取出的容器8;安全防护机构7合围容器操作机构和容器位置调整机构5,并且安全防护机构7具有操作口7a和出入口7b,该操作口7a被构造成用于供容器操作机构从载具9上取出容器8或者将容器8放置在载具9上,出入口7b被构造为用于供托盘进出安全防护机构7围挡的区域。Continuing to refer to FIG. 1, the container palletizing system also includes a
继续参见图1,本实施例中,安全防护机构7包括环绕容器操作机构和容器位置调整机构5并且依次间隔设置的多个立柱70,相邻两个立柱70之间连接有遮挡件71,其中,与目标载具9对应处的两个立柱70之间未设置遮挡件71以形成操作口7a。在方便托盘出入的位置处的两个立柱70之间未设置遮挡件71以形成出入口7b。Continuing to refer to FIG. 1 , in this embodiment, the
容器码垛系统设置安全防护机构7可以阻止无关人员靠近容器操作机构,以防止无关人员无意或故意行为造成容器操作机构损坏,还可以避免容器8意外跌落造成人员伤亡,从而可以提高容器码垛系统的工作安全性和可靠性。The container palletizing system is equipped with a
详细地,本实施例中,遮挡件71包括平行且间隔设置的多个竖直杆和多个水平杆,多个竖直杆和多个水平杆相互固定连接以形成围栏。可以理解,安全防护机构7采用杆件拼装而成,结构简单、制造成本低。在另一些实施例中,遮挡件71可以为整块板材或者是布料等织物。In detail, in this embodiment, the blocking member 71 includes a plurality of vertical rods and a plurality of horizontal rods arranged in parallel and at intervals, and the plurality of vertical rods and the plurality of horizontal rods are fixedly connected to each other to form a fence. It can be understood that the
另外,继续参见图1,该安全防护机构7为方形围栏结构,当然,在满足合围容器操作机构和容器位置调整机构5功能、加工及装配工艺的要求时,安全防护机构7可以为圆形、椭圆形等结构。In addition, continuing to refer to Fig. 1, the
本发明还提供一种应用于上述容器码垛系统的控制方法,参见图9,该控制方法包括如下主要步骤:The present invention also provides a control method applied to the above-mentioned container palletizing system, see Fig. 9, the control method includes the following main steps:
步骤S1000,运动组件带动容器取放组件运动至第一目标位置处,且容器取放组件取出第一目标位置上的容器;Step S1000, the moving component drives the container pick-and-place component to move to the first target position, and the container pick-and-place component takes out the container at the first target position;
步骤S2000,运动组件带动容器取放组件运动至容器位置调整机构处,且容器取放组件将容器放置在容器位置调整机构上;Step S2000, the moving component drives the container pick-and-place component to move to the container position adjustment mechanism, and the container pick-and-place component places the container on the container position adjustment mechanism;
步骤S3000、容器位置调整机构调整容器至预设的第二目标位置;Step S3000, the container position adjustment mechanism adjusts the container to the preset second target position;
步骤S4000,运动组件带动容器码垛组件运动至第二目标位置处,且容器码垛组件取出第二目标位置上的容器;Step S4000, the moving component drives the container palletizing component to move to the second target position, and the container palletizing component takes out the container at the second target position;
步骤S5000,运动组件带动容器码垛组件运动至第三目标位置处,且容器码垛组件将容器码放在第三目标位置上。Step S5000, the moving component drives the container palletizing component to move to the third target position, and the container palletizing component stacks the container on the third target position.
为了便于更好地理解,下面结合图10,以一个具体实施例方式为例来详细说明该控制方法的控制流程。In order to facilitate a better understanding, the control flow of the control method will be described in detail below by taking a specific embodiment as an example with reference to FIG. 10 .
本实施例中第一目标位置位于载具上,第三目标位置位于托盘上。可以理解,本申请的容器码垛系统的控制方法并不仅限于适用于在载具和托盘之间码放容器,其可适用于仓储系统中任何两个目标区域之间的码放容器工作。In this embodiment, the first target position is located on the carrier, and the third target position is located on the pallet. It can be understood that the control method of the container palletizing system of the present application is not limited to stacking containers between carriers and pallets, but can be applied to stacking containers between any two target areas in the storage system.
参见图10,本申请的容器码垛系统的控制方法包括如下详细步骤:Referring to Figure 10, the control method of the container palletizing system of the present application includes the following detailed steps:
S1001、运动组件带动容器取放组件移动至载具上的第一目标位置。S1001. The moving component drives the container pick-and-place component to move to a first target position on the carrier.
需要说明的是,载具中的第一目标位置是指摆放用户想要取出的目标容器的载具的位置,第一目标位置与目标容器对应存储在仓储系统的数据库内,码放容器时从数据库调取即可。It should be noted that the first target position in the carrier refers to the position of the carrier where the target container that the user wants to take out is placed. The first target position and the target container are correspondingly stored in the database of the storage system. The database can be called.
S1002、读取第一目标位置上容器的信息,所述信息包括容器的尺寸。S1002. Read the information of the container at the first target position, where the information includes the size of the container.
如前所述,本申请的容器码垛系统的容器操作机构上设置有第一检测元件,该第一检测元件用于获取目标容器的识别信息,以便确定将要取出的容器是否与目标容器一致,该识别信息中包括容器的尺寸。As mentioned above, the container operating mechanism of the container palletizing system of the present application is provided with a first detection element, the first detection element is used to obtain the identification information of the target container, so as to determine whether the container to be taken out is consistent with the target container, The identification information includes the size of the container.
S1003、容器取放组件通过与第一目标位置的容器的前端面结合以取出容器。S1003. The container pick-and-place component combines with the front surface of the container at the first target position to take out the container.
显然,本实施例中,容器取放组件与容器的前端面配合以取出容器8,如此可以在载具上密集地摆放和码放容器,从而增大载具的容器存储量。Obviously, in this embodiment, the container pick-and-place component cooperates with the front surface of the container to take out the container 8, so that the containers can be densely placed and stacked on the carrier, thereby increasing the container storage capacity of the carrier.
根据本发明的另一些实施例,本发明的容器取放组件也可以通过与容器的底面、侧面或者顶面结合以取出该容器。具体地,该容器取放组件可以通过吸取、推动、夹取、抓取、钩取、抱起、抬升方式中的至少一种取放容器。According to some other embodiments of the present invention, the container pick-and-place assembly of the present invention can also be combined with the bottom surface, side surface or top surface of the container to take out the container. Specifically, the container pick-and-place assembly can pick and place containers by at least one of sucking, pushing, clamping, grabbing, hooking, picking up, and lifting.
S2000、运动组件带动容器取放组件运动至容器位置调整机构处,且容器取放组件将容器放置在容器位置调整机构上。S2000. The moving component drives the container pick-and-place component to move to the container position adjustment mechanism, and the container pick-and-place component places the container on the container position adjustment mechanism.
S3000、容器位置调整机构调整容器至预设的第二目标位置。其中,第二目标位置时预设的运动组件带动容器码垛组件从当前位置运动达到的目标位置。S3000. The container position adjustment mechanism adjusts the container to a preset second target position. Wherein, at the second target position, the preset moving component drives the container palletizing component to move from the current position to the target position.
详细地,结合前文中的容器码垛系统,容器位置调整机构调整容器至预设的第二目标位置的调整方法包括如下步骤:In detail, in combination with the above-mentioned container palletizing system, the adjustment method for the container position adjustment mechanism to adjust the container to the preset second target position includes the following steps:
首先,气缸控制器控制第一活动挡板54位于低位,即位于低位时第一活动挡板54位于第一缓存覆板50的板面下方;其次,容器取放组件2将容器推送到第一缓存覆板50上,然后控制第一活动挡板54上升至高位;再次,控制第二活动挡板55推动容器8至容器8与固定挡板53相抵;最后,控制第三活动挡板56推动容器8至容器8与第一活动挡板54相抵即可,至此将容器由当前位置调整至第二目标位置。First, the cylinder controller controls the first
容器调整至第二目标位置后,本实施例的控制方法继续检测托盘是否满足码放容器的条件,以防止托盘不满足码放容器条件的情况下直接进行后续码放工作而引起的失误。After the container is adjusted to the second target position, the control method of this embodiment continues to detect whether the pallet meets the conditions for stacking the container, so as to prevent errors caused by directly performing subsequent stacking work when the pallet does not meet the conditions for stacking the container.
检测托盘是否满足码放容器的条件包括如下步骤:Detecting whether the pallet meets the conditions for stacking containers includes the following steps:
S3001、检测托盘是否达到预设的第四目标位置。S3001. Detect whether the tray reaches a preset fourth target position.
同样,如前文所述,托盘位置调整机构6包括到位检测元件63,该到位检测元件63被配置成用于检测托盘是否到位预设的第四目标位置。Likewise, as mentioned above, the tray
详细地,到位检测元件63包括相匹配的信号发射部件和信号接收部件,所述信号接收部件被构造为收到所述信号发射部件发射的信号时被触发。该到位检测元件63可以为光电对射传感器。In detail, the
在另一些实施例中,该到位检测元件63可以为接近开关,该接近开关被配置成当托盘到位预设的第四目标位置后被触发。In some other embodiments, the
当步骤S3001检测到托盘到位预设的第四目标位置后,执行步骤S3002,否则执行步骤S3003。When step S3001 detects that the tray has reached the preset fourth target position, step S3002 is executed; otherwise, step S3003 is executed.
S3002、检测托盘上是否有异物。S3002. Detect whether there is a foreign object on the tray.
该步骤的目的在于防止托盘上有异物而无法码放容器问题的发生,以提高成功码放容器的几率。The purpose of this step is to prevent the occurrence of foreign objects on the pallet that prevent the container from being stacked, so as to improve the probability of successfully stacking the container.
当托盘上没有异物时,执行步骤S3004,否则执行步骤S3005。When there is no foreign matter on the tray, go to step S3004, otherwise go to step S3005.
S3003、发出预警信号,以提醒用户或上一级控制系统托盘未到位或者托盘上有异物。S3003. Send out an early warning signal to remind the user or the upper-level control system that the tray is not in place or there is a foreign object on the tray.
S3004、判断容器的尺寸是否小于预定尺寸。S3004. Determine whether the size of the container is smaller than a predetermined size.
需要说明的是,“预定尺寸”是指用户或上一级控制系统预设的允许容器码垛组件单次取出的容器的尺寸。通常情况下,容器的尺寸大小会不同,用户可以根据容器码垛组件的尺寸大小和吸盘的吸附能力设定其单次能取出的容器尺寸,当容器尺寸小于预定尺寸时,容器码垛组件单次可以取出至少两个容器,当容器尺寸大于或等于预定尺寸时,容器码垛组件单次仅可取出一个容器。It should be noted that the "predetermined size" refers to the size of the container that is preset by the user or the upper-level control system and allows the container palletizing assembly to be taken out once. Usually, the size of the container will be different. The user can set the size of the container that can be taken out at a time according to the size of the container palletizing component and the adsorption capacity of the suction cup. When the container size is smaller than the predetermined size, the container palletizing component will be single At least two containers can be taken out at a time. When the size of the container is greater than or equal to the predetermined size, the container palletizing assembly can only take out one container at a time.
当容器的尺寸大于或等于预定尺寸时,执行步骤S4001;When the size of the container is greater than or equal to the predetermined size, perform step S4001;
当容器的尺寸小于预定尺寸时,执行步骤S3005。When the size of the container is smaller than the predetermined size, step S3005 is executed.
S4001、运动组件带动容器码垛组件运动至第二目标位置处,且容器码垛组件通过与第二目标位置上的容器的顶面结合以取出该容器。S4001. The moving component drives the container palletizing component to move to a second target position, and the container palletizing component combines with the top surface of the container at the second target position to take out the container.
显然,本实施例中,容器码垛组件与容器的顶面结合以取出容器8,如此可以在托盘上密集地摆放和码放容器,从而增大托盘的容器存储量。Obviously, in this embodiment, the container stacking assembly is combined with the top surface of the container to take out the container 8, so that the containers can be densely placed and stacked on the pallet, thereby increasing the container storage capacity of the pallet.
根据本发明的另一些实施例,本发明的容器码垛组件也可以通过与容器的底面、侧面结合以取出该容器。具体地,该容器取放组件可以通过吸取或钩取方式取放容器。According to other embodiments of the present invention, the container palletizing assembly of the present invention can also be combined with the bottom surface and the side surface of the container to take out the container. Specifically, the container pick-and-place assembly can pick and place the container by sucking or hooking.
S5001、运动组件带动容器码垛组件运动至托盘上的第三目标位置处,容器码垛组件将取出的容器码放在托盘的第三目标位置上。S5001. The moving component drives the container palletizing component to move to the third target position on the pallet, and the container palletizing component stacks the taken-out container on the third target position on the pallet.
需要说明的是,码放容器的方法可以是基于托盘的工作面的面积以及容器的尺寸,首先容器码垛组件将容器摆放至托盘的工作面上,当托盘的工作面摆放满后,容器码垛组件再将容器摆放到底层容器的上面直至达到允许码放容器的高度。It should be noted that the method of stacking containers can be based on the area of the working surface of the pallet and the size of the container. First, the container palletizing component places the container on the working surface of the pallet. When the working surface of the pallet is full, the container The palletizing component then places the container on top of the bottom container until it reaches a height that allows stacking of the container.
当然,码放容器的方法也可以是先将容器依次叠加至允许的高度,再另起一组依次叠加至允许的高度直至托盘的工作面被摆放满。Of course, the method of stacking the containers can also be to firstly stack the containers to the allowable height, and then start another group to stack up to the allowable height until the working surface of the pallet is fully placed.
S3005、容器码垛组件与位于第二目标位置的容器的顶面结合以取出容器,并将容器排布在排布目标位置上。S3005. The container palletizing component combines with the top surface of the container at the second target position to take out the container, and arranges the container at the target position for arrangement.
需要说明的是,排布目标位置是指容器位置调整机构上的组合平台上的第二缓存覆板上的位置,组合平台的作用在于将小尺寸容器定位后先暂时缓存,待组合容器的尺寸符合预定尺寸后,容器码垛组件再将这些组合容器码放到托盘上,即容器码垛组件单次可以码放多个容器,以减小码放同等数量容器时容器操作机构的运动次数,提高码放效率。It should be noted that the arrangement target position refers to the position on the second buffer cover plate on the combination platform on the container position adjustment mechanism. After meeting the predetermined size, the container palletizing component will put these combined containers on the pallet, that is, the container palletizing component can stack multiple containers at a time, so as to reduce the number of movements of the container operating mechanism when stacking the same number of containers and improve the efficiency of stacking .
S3006、判断排布目标位置上的组合容器尺寸是否小于预定尺寸。S3006. Determine whether the size of the combined container at the arrangement target position is smaller than a predetermined size.
当排布目标位置上的组合容器尺寸小于预定尺寸时,执行步骤S1001,容器取放组件继续从载具上取出容器;When the size of the combined container at the arrangement target position is smaller than the predetermined size, step S1001 is executed, and the container pick-and-place component continues to take out the container from the carrier;
当排布目标位置上的组合容器尺寸大于或者等于预定尺寸时,执行步骤S4002。When the size of the combined container at the arrangement target position is greater than or equal to the predetermined size, step S4002 is executed.
S4002、运动组件带动容器码垛组件运动至排布目标位置处,且容器码垛组件取出位于排布目标位置上的容器。S4002. The moving component drives the container palletizing component to move to the arrangement target position, and the container palletizing component takes out the container at the arrangement target position.
S5002、运动组件带动容器码垛组件运动至托盘中的第三目标位置,容器码垛组件将排布目标位置的多个容器码放在托盘的第三目标位置。S5002. The moving component drives the container palletizing component to move to a third target position in the pallet, and the container palletizing component stacks a plurality of containers arranged at the target position on the third target position of the pallet.
需要说明的是,本实施例中,读取载具上容器的信息的步骤设置在容器取放组件从载具上取出容器前,基于只获取容器的尺寸的目的,在另一些实施例中,该步骤只要位于步骤容器码垛组件从第二目标位置取出容器之前即可。It should be noted that, in this embodiment, the step of reading the information of the container on the carrier is set before the container pick-and-place component takes out the container from the carrier, based on the purpose of only obtaining the size of the container, in other embodiments, This step only needs to be before the container palletizing assembly takes out the container from the second target position.
另外,本实施例中,将检测托盘是否满足码放容器的条件的步骤设置在判断容器尺寸与预定尺寸之间大小关系的步骤之前,其目的在于缩短控制方法的步骤。In addition, in this embodiment, the step of detecting whether the pallet satisfies the conditions for stacking containers is arranged before the step of judging the size relationship between the size of the container and the predetermined size, the purpose of which is to shorten the steps of the control method.
在另一些实施例中,检测托盘是否满足码放容器的条件的步骤也可以设置在判断容器尺寸与预定尺寸之间大小关系的步骤之后。In some other embodiments, the step of detecting whether the pallet satisfies the conditions for stacking containers can also be set after the step of judging the size relationship between the size of the container and the predetermined size.
比如当容器尺寸小于预定尺寸时,在步骤S3006的判断结果为是时再去检测托盘是否满足码放容器的条件,若是则执行步骤S4002,否则执行发出预警信号。For example, when the size of the container is smaller than the predetermined size, if the judgment result of step S3006 is yes, then check whether the pallet meets the conditions for stacking the container, if so, execute step S4002, otherwise execute an early warning signal.
当容器尺寸大于或等于预定尺寸时,直接检测托盘是否满足码放容器的条件,若是则执行步骤S4001,否则执行发出预警信号。When the size of the container is greater than or equal to the predetermined size, directly detect whether the pallet meets the conditions for stacking the container, if so, execute step S4001, otherwise execute to send an early warning signal.
本发明的控制方法中在容器取放组件取出容器之后,先利用容器位置调整机构将容器调整至预设的第二目标位置处,然后容器码垛组件才从第二目标位置上取出该容器码放在托盘上,将容器码垛组件与容器之间的结合位置限定在允许的偏差范围之内,从而能使容器码垛组件可以将容器的码放位置控制在预设的码放位置处,或者可以将容器的实际码放位置与预设的码放位置之间的偏差量控制在允许的偏差范围之内,避免了该容器与在先码放的容器之间和/或后续待码放的容器之间的位置干涉,保证了码放工作顺畅且有序的进行。In the control method of the present invention, after the container pick-and-place component takes out the container, the container position adjustment mechanism is used to adjust the container to the preset second target position, and then the container palletizing component takes out the container from the second target position and stacks it. On the pallet, the combined position between the container palletizing assembly and the container is limited within the allowable deviation range, so that the container palletizing assembly can control the stacking position of the container at the preset stacking position, or the The deviation between the actual stacking position of the container and the preset stacking position is controlled within the allowable deviation range, which avoids the positional interference between the container and the previous stacked container and/or the subsequent container to be stacked , to ensure the smooth and orderly progress of the stacking work.
另外,容器码垛系统上配置组合平台,将尺寸小于预定尺寸的容器8暂时缓存在组合平台上,待组合后达到预定尺寸后再整体由容器码垛组件4码放至托盘上,与不考虑容器8尺寸逐一码放容器8相比,可以提高码垛效率。In addition, a combination platform is configured on the container palletizing system, and the containers 8 smaller than the predetermined size are temporarily buffered on the combination platform. After the combination reaches the predetermined size, the whole is put on the pallet by the
还有,容器操作机构通过两个取出组件,通过容器8的前端面从载具9上取出容器8,而又从容器8的顶面码放容器8,用一个机构完美的实现了上下料及码垛功能,并且还可以密集码放容器,充分利用载具和托盘上的空间,提高载具或托盘的容器摆放能力。In addition, the container operating mechanism takes out the container 8 from the carrier 9 through the front surface of the container 8 through two take-out components, and stacks the container 8 from the top surface of the container 8, and realizes loading and unloading and stacking perfectly with one mechanism Function, and can also densely stack containers, make full use of the space on the carrier and pallet, and improve the container placement capacity of the carrier or pallet.
以上已经描述了本发明的各实施例,上述说明是示例性的,并非穷尽性的,并且也不限于所披露的各实施例。在不偏离所说明的各实施例的范围和精神的情况下,对于本技术领域的普通技术人员来说许多修改和变更都是显而易见的。本文中所用术语的选择,旨在最好地解释各实施例的原理、实际应用或对市场中的技术改进,或者使本技术领域的其它普通技术人员能理解本文披露的各实施例。本发明的范围由所附权利要求来限定。Having described various embodiments of the present invention, the foregoing description is exemplary, not exhaustive, and is not limited to the disclosed embodiments. Many modifications and alterations will be apparent to those of ordinary skill in the art without departing from the scope and spirit of the described embodiments. The terminology used herein is chosen to best explain the principle of each embodiment, practical application or technical improvement in the market, or to enable other ordinary skilled in the art to understand each embodiment disclosed herein. The scope of the invention is defined by the appended claims.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202111402212.9A CN116142811A (en) | 2021-11-19 | 2021-11-19 | Container operating mechanism, container palletizing system and control method thereof |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202111402212.9A CN116142811A (en) | 2021-11-19 | 2021-11-19 | Container operating mechanism, container palletizing system and control method thereof |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN116142811A true CN116142811A (en) | 2023-05-23 |
Family
ID=86358774
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202111402212.9A Pending CN116142811A (en) | 2021-11-19 | 2021-11-19 | Container operating mechanism, container palletizing system and control method thereof |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN116142811A (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN118929208A (en) * | 2024-10-15 | 2024-11-12 | 江苏坤载新材料科技有限公司 | A flexible adsorption type workshop glass transportation device |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102006040053A1 (en) * | 2005-08-30 | 2007-05-24 | Sar-Dat Automation Gmbh | Automation system for handling e.g. fired brick, has conveying device with transferring table designed such that goods are arranged together, and robotic palletizer with gripper to grip goods provided at table and to stack on pallet |
| CN201713138U (en) * | 2010-04-20 | 2011-01-19 | 建滔(佛冈)积层板有限公司 | Automatic plate arranging device |
| CN206731986U (en) * | 2017-04-17 | 2017-12-12 | 哈工大机器人集团有限公司 | A kind of angle steel fully automatic feeding and bar stock cutting by punching system |
| CN208453979U (en) * | 2018-03-21 | 2019-02-01 | 本田汽车零部件制造有限公司 | Positioning device and blanking palletizing system |
| CN110654883A (en) * | 2019-09-23 | 2020-01-07 | 珠海格力智能装备有限公司 | Stacking device |
| CN210709544U (en) * | 2019-10-22 | 2020-06-09 | 济南翼菲自动化科技有限公司 | An automatic collecting device for ampoules |
| CN212497805U (en) * | 2020-06-11 | 2021-02-09 | 南京极智嘉机器人有限公司 | Mechanical arm clamp and cargo sorting and stacking device |
-
2021
- 2021-11-19 CN CN202111402212.9A patent/CN116142811A/en active Pending
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102006040053A1 (en) * | 2005-08-30 | 2007-05-24 | Sar-Dat Automation Gmbh | Automation system for handling e.g. fired brick, has conveying device with transferring table designed such that goods are arranged together, and robotic palletizer with gripper to grip goods provided at table and to stack on pallet |
| CN201713138U (en) * | 2010-04-20 | 2011-01-19 | 建滔(佛冈)积层板有限公司 | Automatic plate arranging device |
| CN206731986U (en) * | 2017-04-17 | 2017-12-12 | 哈工大机器人集团有限公司 | A kind of angle steel fully automatic feeding and bar stock cutting by punching system |
| CN208453979U (en) * | 2018-03-21 | 2019-02-01 | 本田汽车零部件制造有限公司 | Positioning device and blanking palletizing system |
| CN110654883A (en) * | 2019-09-23 | 2020-01-07 | 珠海格力智能装备有限公司 | Stacking device |
| CN210709544U (en) * | 2019-10-22 | 2020-06-09 | 济南翼菲自动化科技有限公司 | An automatic collecting device for ampoules |
| CN212497805U (en) * | 2020-06-11 | 2021-02-09 | 南京极智嘉机器人有限公司 | Mechanical arm clamp and cargo sorting and stacking device |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN118929208A (en) * | 2024-10-15 | 2024-11-12 | 江苏坤载新材料科技有限公司 | A flexible adsorption type workshop glass transportation device |
| CN118929208B (en) * | 2024-10-15 | 2024-12-13 | 江苏坤载新材料科技有限公司 | A flexible adsorption type workshop glass transportation device |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN114394362B (en) | Warehouse-out method and warehouse-in method of warehouse goods and transfer robot | |
| KR20210107766A (en) | Transfer robots, warehouse logistics systems and methods of transporting goods | |
| US20100092272A1 (en) | Apparatus and method for transferring part loads | |
| CN216735893U (en) | Container handling device, warehouse system | |
| CN113104503A (en) | A device for automatic loading and unloading of carton-packed goods on a van | |
| WO2021098008A1 (en) | Product picking system and product picking method | |
| CN112919148B (en) | Non-contact type cold chain container drawing, disinfecting, loading and unloading intelligent equipment | |
| CN115123970B (en) | Container box type packaging unloading and sterilizing equipment | |
| CN108861630B (en) | Side suction unstacking device and unstacking method | |
| CN107826783B (en) | Coating machine automatic collecting plate workbench | |
| CN217915352U (en) | Pile up neatly machine people grabbing device and pile up neatly machine people | |
| WO2024007634A1 (en) | Goods retrieval and feeding device, loading and unloading unit, and order picking system | |
| CN117302808B (en) | Picking workstation, picking system and control method of picking system | |
| CN115973653A (en) | Container taking and delivering assembly, loading and unloading device, picking system and container taking and delivering method | |
| US12187553B2 (en) | Intelligent robotized depalletizer | |
| US20060120850A1 (en) | Workpiece handling system with geostationary ejection function | |
| CN216710953U (en) | Container operating mechanism and container stacking system | |
| CN216037383U (en) | Stacking device for pneumatic trays on conveying line | |
| CN111071127A (en) | Cargo loading and unloading system and cargo loading and unloading method | |
| JP3128358B2 (en) | Automatic picking method and apparatus for stacking sheet packages | |
| JP3425988B2 (en) | Laser processing system | |
| CN222272444U (en) | Automatic corner protection device for baler and baler | |
| EP4371711A1 (en) | A robotic system transfer unit cell and method of operation thereof | |
| CN111409983A (en) | Goods taking device and goods taking method | |
| CN209226124U (en) | Servo feeding, device for discharging |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination |