CN115870750A - Processing equipment and processing method - Google Patents
Processing equipment and processing method Download PDFInfo
- Publication number
- CN115870750A CN115870750A CN202211341685.7A CN202211341685A CN115870750A CN 115870750 A CN115870750 A CN 115870750A CN 202211341685 A CN202211341685 A CN 202211341685A CN 115870750 A CN115870750 A CN 115870750A
- Authority
- CN
- China
- Prior art keywords
- raw material
- processing
- clamping
- module
- frame
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images


Landscapes
- Automatic Tool Replacement In Machine Tools (AREA)
Abstract
Description
技术领域technical field
本发明涉及自动化装备技术领域,特别是涉及一种加工设备及加工方法。The invention relates to the technical field of automation equipment, in particular to a processing equipment and a processing method.
背景技术Background technique
在现有零部件加工当中,对于需要进行钻孔和攻丝的零件而言,一般是在原料当中切割得到胚料,然后将胚料转移固定在加工设备上进行钻孔和攻丝,整个过程需要重复多次将胚料转移固定在加工设备上的步骤,整体的加工效率较低。In the processing of existing parts, for parts that need to be drilled and tapped, the blank is generally cut from the raw material, and then the blank is transferred and fixed on the processing equipment for drilling and tapping. The whole process The steps of transferring and fixing the billets to the processing equipment need to be repeated many times, and the overall processing efficiency is low.
为此,需要设计一种集上下料和加工为一体的加工装置,在加工方面,采用单个加工模块带换刀机构的结构,在进行不同工序的加工时,只能够依次执行每个工序,其加工时间较长,不利于提高生产效率。For this reason, it is necessary to design a processing device that integrates loading, unloading and processing. In terms of processing, a single processing module with a tool change mechanism is adopted. When processing different processes, each process can only be executed sequentially. The processing time is longer, which is not conducive to improving production efficiency.
发明内容Contents of the invention
本发明旨在至少解决现有技术中存在的技术问题之一。为此,本发明提出一种加工装置,能够有效提高生产效率。The present invention aims to solve at least one of the technical problems existing in the prior art. For this reason, the present invention proposes a processing device, which can effectively improve production efficiency.
本发明的加工设备,包括:基座;进料模块,设置在基座上,进料模块用于夹持原料并向右输送;第一加工模块,设置在基座上,第一加工模块位于进料模块后侧,第一加工模块用于为原料钻孔;切割模块,设置在基座上,切割模块位于进料模块右侧,切割装置用于切断原料;第二加工模块,设置在基座上,第二加工模块位于切割模块后侧,第二加工模块用于为原料攻丝。The processing equipment of the present invention includes: a base; a feeding module arranged on the base, and the feeding module is used to clamp raw materials and transport them to the right; a first processing module is arranged on the base, and the first processing module is located on the base On the rear side of the feeding module, the first processing module is used to drill holes for the raw material; the cutting module is arranged on the base, the cutting module is located on the right side of the feeding module, and the cutting device is used to cut the raw material; the second processing module is arranged on the base On the seat, the second processing module is located at the rear side of the cutting module, and the second processing module is used for tapping the raw material.
应用上述加工设备,在整个生产过程当中,进料模块用于夹持长条形原料并向右输送,之后切割模块用于将原料切割成规定长度的料段,第一加工模块用于为钻孔,第二加工模块用于为原料攻丝;由于钻孔、切割和攻丝工位沿着长条形原料的输送方向即左右方向依次设置;在生产过程当中,可以根据需要,将钻孔、切割和攻丝当中的两个或以上的工序同时进行,有效提高生产效率。Using the above-mentioned processing equipment, during the whole production process, the feeding module is used to hold the strip-shaped raw material and transport it to the right, and then the cutting module is used to cut the raw material into sections of specified length, and the first processing module is used for drilling hole, the second processing module is used to tap the raw material; since the drilling, cutting and tapping stations are set in sequence along the conveying direction of the strip-shaped raw material, that is, the left and right directions; during the production process, the drilling can be Two or more processes of cutting, tapping and tapping are carried out at the same time, which can effectively improve production efficiency.
本发明的附加方面和优点将在下面的描述中部分给出,部分将从下面的描述中变得明显,或通过本发明的实践了解到。Additional aspects and advantages of the invention will be set forth in the description which follows, and in part will be obvious from the description, or may be learned by practice of the invention.
附图说明Description of drawings
本发明的上述和/或附加的方面和优点从结合下面附图对实施例的描述中将变得明显和容易理解,其中:The above and/or additional aspects and advantages of the present invention will become apparent and comprehensible from the description of the embodiments in conjunction with the following drawings, wherein:
图1为本发明实施例中加工装置的轴测图;Fig. 1 is the axonometric view of processing device in the embodiment of the present invention;
图2为图1中第一种加工装置另一视角的轴侧图;Fig. 2 is an axonometric view of another viewing angle of the first processing device in Fig. 1;
图3为图1中进料模块的轴测图;Fig. 3 is the axonometric view of feeding module in Fig. 1;
图4为图3中A处的放大图;Fig. 4 is the enlarged view of place A in Fig. 3;
图5为图3中进料模块的俯视图;Fig. 5 is the top view of feeding module in Fig. 3;
图6为图5中D-D向的剖视图;Fig. 6 is a sectional view of D-D direction in Fig. 5;
图7为图2中切割模块的轴侧图;Fig. 7 is an axonometric view of the cutting module in Fig. 2;
图8为图7中切割模块的剖视图;Fig. 8 is a sectional view of the cutting module in Fig. 7;
图9为本发明实施例中另一种加工装置的轴测图;Fig. 9 is an axonometric view of another processing device in the embodiment of the present invention;
图10为图9中另一种加工装置另一视角的轴侧图;Fig. 10 is an axonometric view of another processing device in Fig. 9;
图11为图9中第一加工模块的轴测图;Fig. 11 is the axonometric view of the first processing module in Fig. 9;
图12为图11中第一加工模块的侧视图;Fig. 12 is a side view of the first processing module in Fig. 11;
图13为图12中A处的放大图;Fig. 13 is an enlarged view of place A in Fig. 12;
图14为图10中进料模块以及加工定位部分的轴测图;Fig. 14 is an axonometric view of the feeding module and the processing positioning part in Fig. 10;
图15为图14中进料模块以及加工定位部分的俯视图;Fig. 15 is a top view of the feeding module and the processing positioning part in Fig. 14;
图16为图15中A-A向的剖视图;Fig. 16 is a sectional view of A-A direction in Fig. 15;
图17为图10中切割模块的轴测图;Figure 17 is an axonometric view of the cutting module in Figure 10;
图18为图17中切割模块的剖视图;Fig. 18 is a sectional view of the cutting module in Fig. 17;
上述附图包含以下附图标记。The above-mentioned drawings contain the following reference numerals.
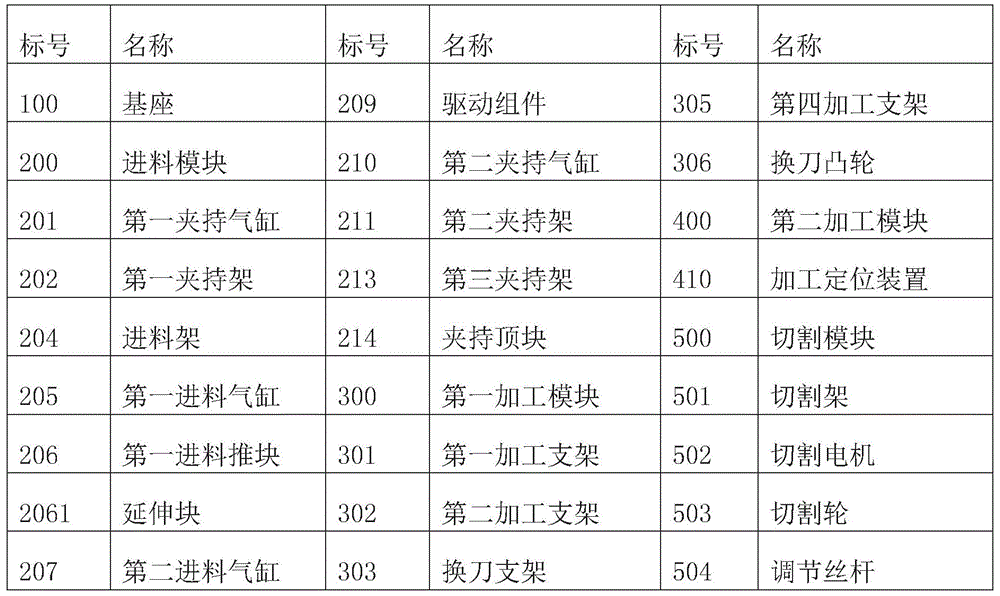
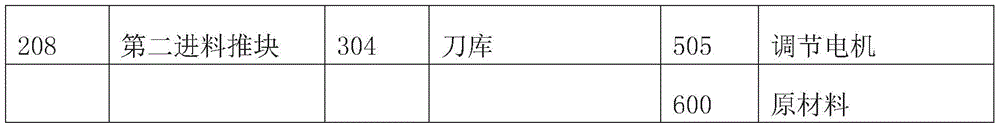
具体实施方式Detailed ways
下面详细描述本发明的实施例,实施例的示例在附图中示出,其中自始至终相同或类似的标号表示相同或类似的元件或具有相同或类似功能的元件。下面通过参考附图描述的实施例是示例性的,仅用于解释本发明,而不能理解为对本发明的限制。Embodiments of the present invention are described in detail below, and examples of the embodiments are shown in the drawings, wherein the same or similar reference numerals denote the same or similar elements or elements having the same or similar functions throughout. The embodiments described below by referring to the figures are exemplary only for explaining the present invention and should not be construed as limiting the present invention.
在本发明的描述中,需要理解的是,涉及到方位描述,例如上、下、前、后、左、右等指示的方位或位置关系为基于附图所示的方位或位置关系,仅是为了便于描述本发明和简化描述,而不是指示或暗示所指的装置或元件必须具有特定的方位、以特定的方位构造和操作,因此不能理解为对本发明的限制。In the description of the present invention, it should be understood that the orientation descriptions, such as up, down, front, back, left, right, etc. indicated orientations or positional relationships are based on the orientations or positional relationships shown in the drawings, and are only In order to facilitate the description of the present invention and simplify the description, it does not indicate or imply that the device or element referred to must have a specific orientation, be constructed and operated in a specific orientation, and thus should not be construed as limiting the present invention.
在本发明的描述中,若干的含义是一个或者多个,多个的含义是两个及两个以上,大于、小于、超过等理解为不包括本数,以上、以下、以内等理解为包括本数。如果有描述到第一、第二只是用于区分技术特征为目的,而不能理解为指示或暗示相对重要性或者隐含指明所指示的技术特征的数量或者隐含指明所指示的技术特征的先后关系。In the description of the present invention, the meaning of several means one or more, and the meaning of multiple means two or more than two. Greater than, less than, exceeding, etc. are understood as not including the original number, and above, below, within, etc. are understood as including the original number . If the description of the first and second is only for the purpose of distinguishing the technical features, it cannot be understood as indicating or implying the relative importance or implicitly indicating the number of the indicated technical features or implicitly indicating the order of the indicated technical features relation.
本发明的描述中,除非另有明确的限定,设置、安装、连接等词语应做广义理解,所属技术领域技术人员可以结合技术方案的具体内容合理确定上述词语在本发明中的具体含义。In the description of the present invention, unless otherwise clearly defined, words such as setting, installation, and connection should be understood in a broad sense, and those skilled in the art can reasonably determine the specific meanings of the above words in the present invention in combination with the specific content of the technical solution.
本实施例公开了两种加工装置即加工设备,图1至图8所示为本实施例中第二种加工装置,图9至图18为本实施例中第一种加工装置,两种加工装置均是由不同模块组合而成,各模块可以根据需要灵活组合成一个新的加工装置,同时具备两种加工装置的特点。This embodiment discloses two kinds of processing devices, that is, processing equipment. Figures 1 to 8 show the second processing device in this embodiment, and Figures 9 to 18 show the first processing device in this embodiment. The devices are all composed of different modules, and each module can be flexibly combined into a new processing device according to the needs, and has the characteristics of the two processing devices at the same time.
图1至图8所示的加工装置,包括:基座100;进料模块200,设置在基座100上,进料模块200用于夹持原料并向右输送;切割模块500,设置在基座100上,切割模块500位于进料模块200右侧,切割模块500用于切断原料;第一加工模块300,设置在基座100上,第一加工模块300位于切割模块500右侧,第一加工模块300用于加工原料;换刀装置,设置在基座100上,换刀装置用于更换第一加工模块300的加工刀具。The processing device shown in Fig. 1 to Fig. 8 includes: a
应用上述加工装置,在整个生产过程当中,进料模块200用于夹持长条形原料并向右输送,之后切割模块500将原料切割成规定长度的料段,而后第一加工模块300用于对料段进行加工,当一个工序加工完成后,可以控制换刀装置为第一加工模块300更换加工刀具,进行下一工序的加工;整个加工过程当中无需针对每个工序设置多个加工工位,仅需要单个工位设置的加工模块和换刀装置即可实现多个工序的加工,有效减少设备占用空间。Using the above-mentioned processing device, during the entire production process, the
如图1,本实施例涉及的加工装置均是用于加工长条形原料也即图1所示的原材料600,其加工过程大致为将原料切断成规定的长度,并对切断后的原料段进行钻孔、攻丝等加工,由于原料呈长条状,在进料过程当中,未切断的原料向右运输,能够将切断后的原料向右顶出,整个加工装置右端设置有一个斜坡,加工完成的原料顺着斜坡向右滑出,完成出料。As shown in Figure 1, the processing devices involved in this embodiment are all used to process strip-shaped raw materials, that is, the
可以理解的是,进料模块200可以采用多种方式进行进料,例如在原料右端设置牵引装置,牵引原料向右移动,或者在原料左端设置推动装置,推动原料向右运动;也可以采用夹持原料的中间部分向右输送的方式,考虑到原料的左右方向长度较长,因此采用夹持原料的中间部分送料的方式能够有效降低设备复杂度,减少设备左右方向上的尺寸。It can be understood that the
如图9至图18所示,第一加工模块300为一个三轴加工模块,其带动主轴电机和夹头在上下、左右和前后三个方向上运动,为原料进行钻孔、攻丝以及铣削等加工,其可以通过平移式三轴组件,也可以采用机械臂等三轴组件带动主轴电机和夹头移动。As shown in Figures 9 to 18, the
如图10所示,切割模块500位于进料模块200右侧指的是切割模块500当中用于切割的部分即切割轮503位于进料模块200右侧,并不意味着切割模块500整体都要位于进料模块200右侧。As shown in Figure 10, the
如图11所示,换刀装置可以采用现有技术当中常用的刀库304设备,如链式刀库304、盘式刀库304等。As shown in FIG. 11 , the tool changing device can adopt a
具体地,如图11至13所示,第一加工模块300包括:第一加工支架301,设置在基座100上;伺服系统,设置在第一加工支架301上;第二加工支架302,设置在第一加工支架301上,伺服系统用于控制第二加工支架302相对于第一加工支架301前后运动;第三加工支架,设置在第二加工支架302上,伺服系统用于控制第三加工支架相对于第二加工支架302左右运动;第四加工支架305,设置在第三加工支架上,伺服系统用于控制第四加工支架305相对于第三加工支架上下运动;主轴电机和夹头,设置在第四加工支架305上,主轴电机用于驱动夹头转动;换刀装置用于更换夹头夹持的刀具;其中,伺服系统包括多个驱动组件209,能够驱动第二加工支架302、第三加工支架和第四加工支架305沿各个方向独立的运动,其中,主轴电机能够驱动夹头,带动其夹持的刀具转动,对原料进行加工。Specifically, as shown in FIGS. 11 to 13 , the
具体地,第一加工模块300还包括设置在第四加工支架305上的打刀缸,打刀缸用于驱动夹头夹持刀具;当需要换刀时,打刀缸能够控制夹头解除夹合,使得换刀装置能够更换夹头当中的刀具,在换到之后,打刀缸可以控制夹头夹合刀具,由主轴电机驱动夹头转动,进行加工;其中,打刀缸和夹头的结构可以参考现有技术当中运用于数控机床上的打刀缸和夹头的相关结构。Specifically, the
如图11至图13所示,换刀装置包括:换刀支架303,设置在第三加工支架顶端,换刀支架303向前延伸;刀库304,转动连接于换刀支架303前端,刀库304设置有多个用于放置刀具的刀位,刀位能够运动至夹持组件下方;其中,刀库304安装在换刀支架303顶端,能够相对于换刀支架303转动至刀位运动至夹头下方,此时刀库304可以更换夹头当中的刀具;在此,可以采用在换刀支架303上设置旋转装置来控制刀库304的转动,也可以采用凸轮等机构控制刀库304相对于换刀支架303的转动。As shown in Figures 11 to 13, the tool changing device includes: a
具体地,如图13所示,换刀装置还包括:换刀凸轮306;设置在第三加工支架上;弹性件,设置在换刀支架303上,弹性件能够驱动第一刀库304抵接换刀凸轮306;当第四加工支架305上升至第一位置时,刀库304能够相对于换刀支架303转动,使得刀位运动至夹持装置下方;当第四加工支架305下降至第二位置时,刀库304能够相对于换刀支架303转动,使得刀位远离夹持装置下方;如图5所示,弹性件能够使得刀库304始终抵接在换刀凸轮306上;当第四加工支架305在伺服系统的控制下,上升至第一位置时,刀库304抵接在凸轮上端较前的位置,刀库304的刀位远离夹头下方,此时可以正常进行加工;当第四加工支架305下降至第二位置时,刀库304抵接在凸轮下端较后的位置,此时刀库304的刀位正好运动至夹头下方,能够为夹头更换刀头。Specifically, as shown in FIG. 13 , the tool changing device further includes: a
在此,刀库304可以采用在机床当中使用的斗笠式刀库304,其本体形如斗笠,外周设置有多个用于放置加工刀具的刀位,通过旋转来切换刀位。Here, the
其中,刀库304上转动连接有限位滚轮,限位滚轮抵接换刀凸轮306;限位滚轮能够起到减少换刀凸轮306磨损的作用,提高换刀凸轮306的寿命。Wherein, the limit roller is connected to the
如图10所示,第一支架设置有让位部,让位部用于容纳切割模块500;其中,第一支架为龙门式结构,其中间的让位部用于容纳切割模块500的部分装置、进出料轨道的部位装置,实现设备的紧凑化。As shown in Figure 10, the first support is provided with a relief part, which is used to accommodate the
如图14至18所示,本实施例中第一种加工装置当中的进料装置即进料模块200,包括:机架;进料架204,设置在机架上;驱动组件209,设置在机架上,驱动组件209用于驱动进料架204向右移动;第三夹持架213,设置在进料架204上,第三夹持架213位于原料上方;顶升机构,设置在进料架204上,顶升机构用于顶升原料以使原料抵接第三夹持架213。As shown in Figures 14 to 18, the feeding device in the first processing device in this embodiment is the
应用上述进料装置,在生产过程当中,顶升机构可以从下部将长条形原料顶起使得长条形原料脱离进料架204,此时原料处于被顶升机构和第三夹持架213共同夹持的状态,驱动组件209通过带动进料架204向右移动,即可带动整个长条形原料向右移动;在长条形原料向右移动指定距离后,顶升机构复位,原料下降,驱动组件209带动进料架204向左移动至原来的位置,进行下一次进料;整个进料过程当中,长条形原料处于被顶升的状态,与设备各部分之间的摩擦大大减少,有效减少了设备与长条形原料的磨损。Using the above-mentioned feeding device, during the production process, the jacking mechanism can lift up the strip-shaped raw material from the lower part so that the strip-shaped raw material is separated from the
在本实施例当中,驱动组件209可以通过多种方式,驱动各部件沿特定方向做直线运动,例如通过电机带动丝杆螺母机构,带动各部件运动,或者通过电机带动齿轮齿条机构带动各部件运动;也可以直接采用直线电机模组带动各部件运动。In this embodiment, the
可以理解,顶升机构也可以通过多种方式顶升原料,例如采用气缸带动推块推动原料上升,或者采用夹爪机构从上方抓取原料等。It can be understood that the jacking mechanism can also lift the raw material in various ways, such as using a cylinder to drive a push block to push the raw material up, or using a gripper mechanism to grab the raw material from above.
具体地,如图16所示,顶升机构包括:夹持顶块214,设置在进料架204上,夹持顶块214位于原料下方;第二进料气缸207,设置在进料架204上,第二进料气缸207用于驱动夹持顶块214升降;其中,第二进料气缸207采用薄型气缸,驱动夹持顶块214从上方顶升原料;当向右进料后,第二进料气缸207带动夹持顶块214缩回,进料架204向左回位,能够避免夹持顶块214与原料发生剐蹭。Specifically, as shown in Figure 16, the jacking mechanism includes: clamping
为了适应不同原料的加工,进料装置还包括:第一进料气缸205,设置在进料架204上,第一进料气缸205用于驱动第三夹持架213升降;在夹持顶块214上升时,可以控制第一进料气缸205控制第三夹持架213下降,最终将原料抬升至特定的高度并夹合后进料,实现了进料时原料高度位置可调,能够充分适应不同规格原料的进料。In order to adapt to the processing of different raw materials, the feeding device also includes: a
如图16所示,第一进料气缸205有两个,两个第一进料气缸205均用于驱动第三夹持架213升降;其中,两个第一进料气缸205分别设置在进料架204的前后两侧,从前后两侧同时驱动第三夹持架213升降,保证其升降稳定性。As shown in Figure 16, there are two
为了减少进料架204回位时与原料之间的摩擦,进料架204上表面设置有润滑部,润滑部能够抵接原料的下表面;在进料后,夹持顶块214下降,进料架204向左回位,润滑部与原料相对滑动,减少摩擦;其中润滑部可以采用油封,也可以采用特氟龙等润滑材料制作。In order to reduce the friction between the
具体地,进料架204上设置进料滚轮,进料滚轮的轴向沿前后方向,当进料架204向左回位时,进料滚轮能够相对于原料滚动,进一步减少摩擦。Specifically, feeding rollers are arranged on the
如图14所示,进料装置还包括:限位部,设置在机架上;推动装置,设置在机架上,推动装置用于向前推动原料,使得原料抵接限位部;限位部和推动装置均位于进料架204左侧;当原料从左端输入时,推动装置能将原料向前推动,使得原料抵接到限位部,保证原料前后方向的位置准确,便于原料精准的穿过进料架204的夹持部分,保证进料的位置精度。As shown in Figure 14, the feeding device also includes: a limiting part, which is arranged on the frame; a pushing device, which is arranged on the frame, and the pushing device is used to push the raw material forward so that the raw material abuts the limiting part; Both the upper part and the pushing device are located on the left side of the
其中,推动装置包括:第一夹持架202,设置在机架上;第一夹持气缸201,设置在机架上,第一夹持气缸201用于推动第一夹持架202向前运动,使得第一夹持架202向前推动原料;其中,第一夹持气缸201能够驱动第一夹持架202向前移动,推动原料向前;当然也可以采用电机带动直线运动机构,或者采用直线模组等装置,推动原料向前抵接限位部。Wherein, the pushing device includes: a
如图14、图15所示,进料装置还包括:第二夹持架211,设置在机架上,第二夹持架211能够相对于机架上下移动;第二夹持气缸210,设置在机架上,第二夹持气缸210用于驱动第二夹持架211下降,使得第二夹持架211向下抵接原料;第二夹持架211和第二夹持气缸210位于进料架204右侧;在进料完成后进料架204回位的过程当中,第二夹持架211能够在进料架204右侧固定原料,将原料压在轨道上,保证进料架204回位过程当中原料不会向左移动。As shown in Figure 14 and Figure 15, the feeding device also includes: a
具体地,第二夹持气缸210有两个,两个第二夹持气缸210均用于驱动第二夹持架211升降;如图14所示,两个第二夹持气缸210位于前后两端,同时驱动第二夹持架211升降。Specifically, there are two
如图14、图15所示,切割模块500的切割架501、切割电机502等部分位于让位部当中,切割轮503位于第二夹持架211和加工定位装置410之间;在加工时,原料从左到右依次经过进料、切断、加工后,从右端出料,也即加工定位装置410将切断后的原料夹持定位,使得第一加工模块300加工精度较高;当加工完成后,加工定位装置410回位,加工后的原料在左端原料的推动下向右运动,从出料端滑出。As shown in Figures 14 and 15, the cutting
对进料模块200而言,进料方法包括如下步骤:S100、控制顶升机构将原料顶升,使得原料向上抵接第三夹持架213;S200、控制驱动组件209,带动进料架204向右移动,使得原料向右移动;S300、控制顶升机构带动原料下降,使得原料下降至落回到进料架204上;其中S100至S300依次执行;For the
特别地,在S300之后,还有步骤S400,即控制驱动装置,带动进料架204向左运动,为下一次进料做准备;In particular, after S300, there is a step S400, that is, to control the driving device to drive the
在步骤S100当中,在顶升机构顶升原料的同时,第三夹持架213也在第一进料气缸205的驱动下向下运动,使得第三夹持架213和顶升机构夹持原料。In step S100, while the material is being lifted by the jacking mechanism, the
如图14所示,本实施例第一种加工装置的进料模块200,是具有多方向进料定位设计的,其中多方向进料定位装置即进料模块200,包括:机架,设置有限位部;进料架204,设置在机架上;夹持装置,设置在进料架204上,夹持装置用于夹持原料;驱动组件209,设置在机架上,驱动组件209用于驱动进料架204向右移动;第一定位装置,设置在机架上,第一定位装置用于推动原料,使得原料沿前后方向抵接限位部;第二定位装置,设置在机架上,第二定位装置用于推动原料,使得原料沿上下方向抵接限位部。As shown in Figure 14, the
在进料过程当中,可以控制夹持装置夹持原料,然后控制驱动组件209带动进料架204向右移动,使得夹持装置带动整个原料向右移动;当原料在夹持装置的带动下向右运动一段距离后,夹持装置解除对原料的夹持,此时可以控制第一定位装置和第二装置推动原料,使得原料分别沿前后方向和上下方向抵接限位部,使得原料在进料之外的过程同时受到沿前后方向和上下方向的抵接作用力,在便于进料的同时提高了原料在进料之外的其他工序当中的位置精度。During the feeding process, the clamping device can be controlled to clamp the raw material, and then the driving
具体地,在原料切割的过程当中,可以在控制第三夹持架213下降,压住原料,同时控制加工定位装置410推动原料,将原料定位,保证了切割轮503切断原料时切断部分的稳定,提高整个加工过程的精度。Specifically, in the process of raw material cutting, the
如图14所示,为了保证进料架204左右滑动的稳定性,进料模块200还包括设置在机架上的滑轨,滑轨沿左右方向延伸,进料架204与滑轨滑动配合。As shown in FIG. 14 , in order to ensure the stability of the left and right sliding of the
具体地,滑轨有两个,两个滑轨沿前后方向间隔分布,驱动组件209位于两个滑轨之间的间隔当中;将两个滑轨间隔设置,能够对进料架204起到较好的承托和限位作用,同时两个滑轨之间的间隔空间正好用于布置驱动组件209,提高了整个设备的紧凑程度。Specifically, there are two slide rails, and the two slide rails are spaced apart along the front-to-back direction, and the
如图17、图18所示,切割装置也即切割模块500包括:机架;切割架501,设置在机架上;驱动组件209,设置在机架上,驱动组件209用于驱动切割架501前后移动;切割驱动组件209,设置在切割架501上;切割轮503,设置在切割驱动组件209上,切割驱动组件209用于驱动切割轮503转动;调节组件,设置在切割架501上,调节组件用于调节切割驱动组件209的上下位置。As shown in Fig. 17 and Fig. 18, the cutting device, that is, the
应用上述切割装置,在生产过程当中,驱动组件209带动切割架501前后移动,切割驱动组件209带动砂轮转动,使得砂轮在转动的同时前后移动,对长条形原料进行切割;当长条形原料的料厚改变时,可以控制调节组件,改变切割驱动组件209和切割轮503的上下位置,使得切割轮503的上边缘高于原料的上边缘,在切割时能够充分切断原料;通过调节组件对于切割驱动组件209和切割轮503位置的调整,能够适应不同厚度规格的原料的加工,提高设备的灵活性。Using the above-mentioned cutting device, during the production process, the
其中,调节组件可以通过多种方式调节切割驱动组件209的上下位置,例如在切割架501上设置沿上下方向排布的多个固定位置,手动将切割驱动组件209安装在其中一个固定位置上;或者采用电机带动齿轮齿条等直线运动机构驱动切割驱动组件209上下运动等。Wherein, the adjustment assembly can adjust the up and down position of the cutting
具体地,调节组件包括:调节丝杆504,转动设置在切割架501上,调节丝杆504沿上下方向延伸;调节螺母,与调节丝杆504螺纹配合,调节螺母与切割驱动组件209连接;当需要调节切割驱动组件209的上下位置时,只需转动丝杆即可,由于丝杆螺母机构的反向自锁特性,在调节完成后无需设置其他固定装置,即可让调节螺母和切割驱动组件209保持调节后的位置;其中,可以通过手动驱动的方式驱动丝杆转动,也可以通过电机等设备驱动调节丝杆504转动,实现切割驱动组件209上下位置调节的自动化。Specifically, the adjustment assembly includes: an
如图17、图18所示。调节组件还包括:调节电机505,设置在切割架501上,调节电机505用于驱动调节丝杆504转动。As shown in Figure 17 and Figure 18. The adjustment assembly further includes: an
具体的,调节组件还包括带传动组,调节电机505通过带传动组驱动调节丝杆504转动;其中,传动组包括主动轮、从动轮以及连接主动轮和从动轮的同步带;主动轮连接电机输出轴,从动轮连接丝杆;通过传动组的设置能够使得调节电机505和调节丝杆504异轴布置,可以将调节电机505布置在丝杆后方的空旷位置,提高设备的空间利用率。Specifically, the adjustment assembly also includes a belt transmission group, and the
其中,切割驱动组件209包括设置在切割架501上的切割电机502,切割电机502用于驱动切割轮503转动,调节螺母与切割电机502的壳体连接;切割架501上设置有滑轨,滑轨沿上下方向延伸,切割电机502的壳体与滑轨滑动配合。Wherein, the cutting
应用本实施例第一种加工装置的加工方法,包括如下步骤:S100、控制进料模块200,夹持原料并向右输送;S200、当原料运输至第一加工位置时,控制第一加工模块300为原料钻孔;S300、当原料运输至切割位置时,控制第一加工模块300切割原料;S400、当切割后的原料运输至第二加工位置时,控制第一加工模块300为原料攻丝。The processing method using the first processing device of this embodiment includes the following steps: S100. Control the
其中,S100的具体步骤可以参考上述进料模块200的进料步骤。Wherein, the specific steps of S100 can refer to the feeding step of the
可以理解,基于加工装置的具体结构,S300和400两个步骤可以同步进行,也即当进料装置带动原料向右移动到指定位置后,用第二夹持架211向下固定原料的同时,用加工定位装置410向前固定原料,然后同时进行切割以及加工工序;在切割和加工均完成后即可出料。It can be understood that, based on the specific structure of the processing device, the two steps of S300 and 400 can be performed simultaneously, that is, when the feeding device drives the raw material to move to the right to the designated position, while the
如图14所示,本实施例中的加工装置,为实现定位精准还设置有加工定位装置410,具体地加工装置包括:基座100,设置有限位部;第一加工模块300,设置在基座100上,第一加工模块300位于限位部一侧,第一加工模块300用于加工原料;切割模块500,设置在基座100上,切割模块500位于第一加工模块300左侧,切割模块500用于切断原料;加工定位装置410,设置在基座100上,加工定位装置410位于第一加工模块300一侧,加工定位装置410能够推动原料以使原料抵接限位部。As shown in Figure 14, the processing device in this embodiment is also provided with a
应用上述装置,在加工过程当中,夹持装置能够推动原料使得原料抵接轨道部,起到对原料的定位作用,使得原料在位置精度较高的情况下被第一加工模块300加工;在加工完毕后,夹持装置复位,加工完毕的部分即可向右运输,完成出料;整个加工过程当中,由于原料的位置精度较高,第一加工模块300对于原料的加工精度也有较大提高。With the above-mentioned device, during the processing, the clamping device can push the raw material so that the raw material abuts against the track portion, which plays a role in positioning the raw material, so that the raw material is processed by the
具体地,基座100上设置有限位块,限位块位于加工定位装置410前侧,加工定位装置410能够向前推动原料,使得原料抵接在限位块上,实现原料前后方向的精准定位。Specifically, a limit block is provided on the
具体地,加工定位装置410包括:加工定位气缸,设置在基座100上;加工定位推块,设置在基座100上,加工定位气缸能够驱动加工定位推块前后移动,使得加工定位推块能够推动原料;当然,也可以采用电机或者液压缸等部件,驱动加工定位推块推动原材料600。Specifically, the processing and
具体地,加工定位装置410有两个,两个加工定位装置410沿左右方向分布;两个加工定位装置410能够沿左右方向,也即原料的长度方向充分固定原料,确保第一加工模块300加工原料时原料位置的稳定。Specifically, there are two processing
在本实施例当中,机架指的是每个模块上承载各个部件的部分,机架可以是基座100的一部分,也可以是安装在基座100上的某个支架。In this embodiment, the rack refers to the part of each module that carries various components, and the rack may be a part of the base 100 or a certain bracket installed on the
如图1至图8,是本实施例第一种加工装置即加工设备,包括:基座100;进料模块200,设置在基座100上,进料模块200用于夹持原料并向右输送;第一加工模块300,设置在基座100上,第一加工模块300位于进料模块200后侧,第一加工模块300用于为原料钻孔;切割模块500,设置在基座100上,切割模块500位于进料模块200右侧,切割装置用于切断原料;第二加工模块400,设置在基座100上,第二加工模块400位于切割模块500后侧,第二加工模块400用于为原料攻丝。As shown in Figures 1 to 8, it is the first processing device of this embodiment, that is, processing equipment, including: a base 100; a
应用上述加工设备,在整个生产过程当中,进料模块200用于夹持长条形原料并向右输送,之后切割模块500用于将原料切割成规定长度的料段,第一加工模块300用于为钻孔,第二加工模块400用于为原料攻丝;由于钻孔、切割和攻丝工位沿着长条形原料的输送方向即左右方向依次设置;在生产过程当中,可以根据需要,将钻孔、切割和攻丝当中的两个或以上的工序同时进行,有效提高生产效率。Using the above-mentioned processing equipment, during the entire production process, the
其中,第一加工模块300设置在进料模块200后侧,其具有一个三轴组件,带动主轴电机和钻头用于对进料装置上的原料进行钻孔加工;而第二加工模块400位于切割模块500后侧,能够对切割后的原料段进行攻丝加工;由于第一加工模块300和第二加工模块400为两个独立运行的模块,因此可以同时对原料的不同部分进行钻孔和攻丝加工。Wherein, the
具体地,在加工过程当中,进料模块200将原料向右移动至规定位置,然后将原料固定,此时第一加工模块300的钻孔、切割模块500的切割以及第二加工模块400的攻丝可以同时进行;在加工完成后,进料模块200继续向右移动原料,并将已经加工完成的原料段向右顶出,然后进行下一次加工,做到了在一段时间内同时进行多个工序。大大节约加工时间。Specifically, during the processing, the
如图1所示,第一加工模块300的主机架大致沿前后方向延伸,其主轴电机、夹头和刀具位于原料上方;第二加工模块400的主机架沿左右方向,也即与原料长度方向平行的方向分布在原料的后侧,其主机架向前延伸,使得主轴电机、夹头和加工刀具位于原料上方;与第一种加工装置不同,第二中加工装置的加工定位装置410设置在第二加工模块400前侧和原料前侧,其向后推动切断后的原料段使其抵接限位部。As shown in Figure 1, the main frame of the
具体地,如图3至图5所示,进料模块200包括:进料架204,设置在基座100上;驱动组件209,设置在基座100上,驱动组件209用于驱动进料架204向右移动;夹持组件,设置在进料架204上,夹持组件用于夹持原料;其中,夹持组件夹持原料后,驱动组件209带动进料架204向右移动,完成对原料的运输;待运输完成后夹持组件松开原料,驱动组件209带动进料架204向左复位,进行下一次进料。Specifically, as shown in FIGS. 3 to 5 , the
其中,夹持组件上还设置有避让部,具体地,进料模块200也即进料装置包括:机架;进料架204,设置在机架上,进料架204上设置有限位部;驱动组件209,设置在机架上,驱动组件209用于驱动进料架204向右移动;夹持机构,设置在进料架204上,夹持机构用于与限位部一同夹持原料;夹持机构上开设有避让部,避让部用于避让加工模块。Wherein, the clamping assembly is also provided with an avoiding part, specifically, the
在生产过程当中,夹持机构与限位部一同夹持长条形原料,然后驱动组件209驱动进料架204向右移动,带动长条形原料向右移动,当长条形原料移动到位后,进料装置一旁的加工模块即可对原料进行加工,在加工过程当中,避让部能够防止加工模块在加工移动的过程当中与夹持机构碰撞,有效降低设备因部件干涉导致损坏的可能。During the production process, the clamping mechanism and the limit part clamp the strip-shaped raw material together, and then the driving
如图1所示,由于第一加工模块300设置在进料模块200后侧,在加工时,加工刀具和夹头容易和进料模块200上的部件干涉,因此要在夹持机构上开设避让机构,用于避让第一加工模块300上的加工刀具和夹头。As shown in Figure 1, since the
更具体地,夹持机构包括:第一进料气缸205,设置在进料架204上;第一进料推块206,设置在进料架204上,第一进料气缸205能够推动第一进料推块206前后移动;延伸块2061,设置在第一进料推块206前侧,延伸块2061用于抵接原料,延伸块2061低于第一进料推块206,延伸块2061和第一进料推块206共同形成避让部;也即,第一进料推块206在第一进料气缸205的推动下前后移动,推动原料使得原料受到夹持;在此由于延伸块2061低于第二进料推块208,在保证夹持效果的前提下,延伸块2061和第二进料推块208之间能够形成有凹陷的避让部。More specifically, the clamping mechanism includes: a
如图4所示,第一进料推块206上设置有调节装置,调节装置用于调节延伸块2061相对于第一进料推块206的高度;其中,调节装置能够通过多种方式调节延伸快的高度,用以适应不同料厚的原料的夹持,例如通过伺服装置带动升降机构,控制延伸块2061相对于第一进料推块206升降,或者在第一进料推块206上设置多个固定位置,手动将延伸块2061安装在其中一个固定位置上。As shown in Figure 4, an adjustment device is provided on the first
具体地,调节装置包括多个固定机构,多个固定机构沿第一进料推块206的上下方向间隔分布,延伸块2061能够可拆卸地与其中一个固定机构固定;固定机构包括设置在第一进料推块206上的固定孔,固定孔沿前后方向贯穿第一进料推块206;此时可以通过用螺钉穿过其中一组固定孔固定延伸块2061的方式来固定延伸块2061;当然,也可以设置卡扣等其他方式,固定延伸块2061。Specifically, the adjustment device includes a plurality of fixing mechanisms, which are distributed at intervals along the up and down direction of the first
在本实施例第二种加工装置当中,进料架204上也设置有滑轨,滑轨沿前后方向延伸,第一进料推块206与滑轨滑动配合。In the second type of processing device in this embodiment, a slide rail is also provided on the
如图3、图5所示,夹持组件包括设置在进料架204上的两个气动夹块,两个气动夹块分别位于原料的前后两侧,两个气动夹块能够一同沿前后方向夹持原料;其中,采用两个气动夹块夹持原料的方式,能够大大减少进料时原料沿前后方向的位移,确保原料的前后位置精度。As shown in Figure 3 and Figure 5, the clamping assembly includes two pneumatic clamping blocks arranged on the
其中,进料架204前侧设置有第一进料气缸205,第一进料气缸205驱动连接有第一进料推块206,第一进料推块206前侧连接有延伸块2061,延伸块2061低于第一进料推块206且延伸块2061上下位置可调;而进料架204后侧设置有第二进料气缸207,第二进料气缸207驱动连接有第二进料推块208,第二进料推块208前侧也连接有延伸块2061,延伸块2061低于第二进料推块208且相对于第二进料推块208上下位置可调,调节方式与第一进料推块206类似;在进料过程当中,第一进料推块206上的延伸块2061和第二进料推块208上的延伸块2061同时向内,一同夹合原料。Wherein, the front side of the
如图3至图6所示的进料装置,其机架左侧,位于进料架204左方设置有第一夹持架202和第一夹持气缸201,第一夹持气缸201有两个,分别设置在第一夹持架202的前后两侧,两个第一夹持气缸201均用于驱动第一夹持架202下降至压住原料;机架右侧,位于进料架204右端的位置还设置有第二夹持架211和第二夹持气缸210,第二夹持气缸210也有两个,分布在第二夹持架211的前后两端,两个额第二夹持气缸210同时驱动第二夹持架211下降,压住原料;其中,切割模块500的切割轮503位于第二夹持架211右侧,也即第二夹持架211和第二加工模块400之间的位置。As shown in Fig. 3 to Fig. 6, the left side of the frame is provided with the
如图7至图8所示,本实施例第一种加工装置的切割模块500,结构可以参考本实施例第二中加工装置当中的切割模块500;其也具有调节丝杆504和调节螺母,只是此处的切割模块500没有设置调节电机505,而是在调节丝杆504上端设置有转动部,通过人工搬动转动部转动的方式,手动调节切割驱动装置的上下位置。As shown in Figures 7 to 8, the structure of the
采用本实施例第一种加工装置的加工方法,包括如下步骤:S100、控制进料模块200,夹持原料并向右输送;S200、当原料运输至第一加工位置时,控制第一加工模块300为原料钻孔;S300、当原料运输至切割位置时,控制第一加工模块300切割原料;S400、当切割后的原料运输至第二加工位置时,控制第一加工模块300为原料攻丝。The processing method using the first processing device in this embodiment includes the following steps: S100. Control the
其中,基于本实施例第一种加工装置的结构,步骤S200至S400可以同时运行,也即执行步骤S100的进料步骤之后,控制第一夹持架202和第二夹持架211下降并压住原料,同时控制加工定位装置410向后推动原料,实现原料的定位后;同时完成控制第一加工模块300进行钻孔加工、控制切割模块500进行切割以及控制第二加工模块400进行攻丝的操作;在下一次进料时,原料向右移动即可将加工完成的原料段向右顶出,完成出料;对于某一段原料而言,其经历的加工过程依次为钻孔、切断以及攻丝。Wherein, based on the structure of the first processing device in this embodiment, steps S200 to S400 can be run simultaneously, that is, after the feeding step of step S100 is performed, the
上面结合附图对本发明实施例作了详细说明,但是本发明不限于上述实施例,在所属技术领域普通技术人员所具备的知识范围内,还可以在不脱离本发明宗旨的前提下作出各种变化。The embodiments of the present invention have been described in detail above in conjunction with the accompanying drawings, but the present invention is not limited to the above-mentioned embodiments, and within the scope of knowledge of those of ordinary skill in the art, various modifications can be made without departing from the spirit of the present invention. Variety.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202211341685.7A CN115870750A (en) | 2022-10-28 | 2022-10-28 | Processing equipment and processing method |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202211341685.7A CN115870750A (en) | 2022-10-28 | 2022-10-28 | Processing equipment and processing method |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN115870750A true CN115870750A (en) | 2023-03-31 |
Family
ID=85759143
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202211341685.7A Pending CN115870750A (en) | 2022-10-28 | 2022-10-28 | Processing equipment and processing method |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN115870750A (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN118357731A (en) * | 2024-01-30 | 2024-07-19 | 厦门华谱科技有限公司 | Fully automatic cutting, punching and attacking machine |
| CN119820312A (en) * | 2025-01-22 | 2025-04-15 | 佛山市广隆精密科技有限公司 | Copper terminal processing automation equipment |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN213730398U (en) * | 2020-10-30 | 2021-07-20 | 佛山市明州机械有限公司 | Drilling and cutting machine |
| CN215146625U (en) * | 2021-05-06 | 2021-12-14 | 常州牧云自动化设备有限公司 | A multifunctional aluminum processing machine |
| CN114770113A (en) * | 2022-04-02 | 2022-07-22 | 深圳海诚装备技术有限公司 | Long strip-shaped raw material processing equipment and method |
| CN115106781A (en) * | 2022-06-10 | 2022-09-27 | 深圳海诚装备技术有限公司 | An automatic tool changing type long strip raw material processing device |
-
2022
- 2022-10-28 CN CN202211341685.7A patent/CN115870750A/en active Pending
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN213730398U (en) * | 2020-10-30 | 2021-07-20 | 佛山市明州机械有限公司 | Drilling and cutting machine |
| CN215146625U (en) * | 2021-05-06 | 2021-12-14 | 常州牧云自动化设备有限公司 | A multifunctional aluminum processing machine |
| CN114770113A (en) * | 2022-04-02 | 2022-07-22 | 深圳海诚装备技术有限公司 | Long strip-shaped raw material processing equipment and method |
| CN115106781A (en) * | 2022-06-10 | 2022-09-27 | 深圳海诚装备技术有限公司 | An automatic tool changing type long strip raw material processing device |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN118357731A (en) * | 2024-01-30 | 2024-07-19 | 厦门华谱科技有限公司 | Fully automatic cutting, punching and attacking machine |
| CN119820312A (en) * | 2025-01-22 | 2025-04-15 | 佛山市广隆精密科技有限公司 | Copper terminal processing automation equipment |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN109877654B (en) | Intelligent integrated machine tooling production system of many manipulators | |
| CN114453496B (en) | Stamping forming equipment for electric shaver blade | |
| CN115106781A (en) | An automatic tool changing type long strip raw material processing device | |
| CN217571749U (en) | Automatic tool changing type long strip raw material processing device | |
| CN116021285B (en) | Integrated machine tool for workpiece machining | |
| CN106378629A (en) | Three-dimensional machining equipment for precise and micro, small, short and long shafts | |
| CN117548727A (en) | Metal plate shearing device | |
| CN112372354A (en) | Loading and unloading device of numerical control lathe | |
| CN218476077U (en) | Cutting device and processing device | |
| CN218397158U (en) | Feeding device | |
| CN115106798A (en) | Aluminum alloy section processing technology and equipment thereof | |
| CN119216629B (en) | A deep hole machining equipment and its usage method for spacecraft components | |
| CN213672432U (en) | Full-automatic laser pipe cutting machine | |
| CN115502768A (en) | A CNC four-axis automatic feeding engraving and milling machine for the medical industry | |
| CN113245850A (en) | Suspender production system and machining process | |
| CN114700743A (en) | An automatic drilling and tapping compound processing device | |
| CN210147588U (en) | Automatic feeding device and drill bit machining equipment with same | |
| CN113927303A (en) | Workpiece drilling and tapping system | |
| CN115847159A (en) | Feeding device and feeding method | |
| CN115570388A (en) | A processing device and processing method | |
| CN112729987A (en) | Full-automatic sample preparation detection mechanism and method | |
| CN217837496U (en) | A automatic unloading equipment of going up of general type for complicated part | |
| CN218476308U (en) | Processing device with accurate positioning | |
| CN218397159U (en) | Multi-direction feeding positioning device | |
| CN218363568U (en) | Feeding device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination |