CN115369780A - Balance device and method for asymmetric stressed cantilever beam - Google Patents
Balance device and method for asymmetric stressed cantilever beam Download PDFInfo
- Publication number
- CN115369780A CN115369780A CN202211099642.2A CN202211099642A CN115369780A CN 115369780 A CN115369780 A CN 115369780A CN 202211099642 A CN202211099642 A CN 202211099642A CN 115369780 A CN115369780 A CN 115369780A
- Authority
- CN
- China
- Prior art keywords
- rod
- nut
- cantilever beam
- tension
- anchor ring
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Classifications
-
- E—FIXED CONSTRUCTIONS
- E01—CONSTRUCTION OF ROADS, RAILWAYS, OR BRIDGES
- E01D—CONSTRUCTION OF BRIDGES, ELEVATED ROADWAYS OR VIADUCTS; ASSEMBLY OF BRIDGES
- E01D21/00—Methods or apparatus specially adapted for erecting or assembling bridges
- E01D21/10—Cantilevered erection
- E01D21/105—Balanced cantilevered erection
-
- E—FIXED CONSTRUCTIONS
- E01—CONSTRUCTION OF ROADS, RAILWAYS, OR BRIDGES
- E01D—CONSTRUCTION OF BRIDGES, ELEVATED ROADWAYS OR VIADUCTS; ASSEMBLY OF BRIDGES
- E01D21/00—Methods or apparatus specially adapted for erecting or assembling bridges
- E01D21/06—Methods or apparatus specially adapted for erecting or assembling bridges by translational movement of the bridge or bridge sections
Landscapes
- Engineering & Computer Science (AREA)
- Architecture (AREA)
- Civil Engineering (AREA)
- Structural Engineering (AREA)
- Bridges Or Land Bridges (AREA)
Abstract
本发明属于桥梁建造技术领域,公开了一种非对称受力悬臂梁的平衡装置及方法,包括压力检测装置、张拉装置和控制装置,压力检测装置设置在吊装设备的支腿与悬臂梁之间,控制装置能够接收压力检测装置的传输信号,张拉装置包括抗拉束、张拉机构和索力动测仪,张拉机构包括支座以及与支座连接的千斤顶、螺母组件和拧紧组件,能够对抗拉束施加拉力以传递至悬臂梁进行平衡。非对称受力悬臂梁的平衡方法,通过千斤顶、螺母组件和拧紧组件配合,可以对抗拉束进行多次张拉,避免了使用控制十分困难的轴力伺服系统辅助进行对悬臂梁的平衡,减少了施工成本,降低了工程作业的控制难度,保证了施工安全,大大提高了施工效率。

The invention belongs to the technical field of bridge construction, and discloses a balancing device and method for an asymmetrically stressed cantilever beam, including a pressure detection device, a tensioning device and a control device, and the pressure detection device is arranged between the outrigger of the hoisting equipment and the cantilever beam During the period, the control device can receive the transmission signal of the pressure detection device. The tension device includes a tension beam, a tension mechanism and a cable force dynamic tester. The tension mechanism includes a support and a jack connected to the support, a nut assembly and a tightening assembly. , which can be balanced by applying tension to the beam against the beam for transfer to the cantilever beam. The balance method of the asymmetrically stressed cantilever beam, through the cooperation of the jack, the nut assembly and the tightening assembly, can perform multiple tensions on the anti-tension beam, avoiding the use of the axial force servo system which is very difficult to control to assist in balancing the cantilever beam, reducing The construction cost is reduced, the control difficulty of the engineering operation is reduced, the construction safety is ensured, and the construction efficiency is greatly improved.
Description
技术领域technical field
本发明涉及桥梁建造技术领域,尤其涉及一种非对称受力悬臂梁的平衡装置及方法。The invention relates to the technical field of bridge construction, in particular to a balancing device and method for an asymmetrically stressed cantilever beam.
背景技术Background technique
在桥梁施工中,预制节段悬臂拼装工艺以其环境影响小、质量可靠、施工速度快、工期短等优势,获得了广泛应用。预制节段悬臂拼装工艺是将桥梁的主梁划分成若干段进行预制,然后运送到施工地进行拼接,参见图1,当下部的桥墩结构200与始发块300形成的T形结构完成后,吊装设备100将预制梁段逐块地吊装到T形结构的端部进行拼装,多个预制梁段形成的结构即为悬臂梁,悬臂梁的长度不断增加,直至多个T形结构合拢,完成全桥施工。In bridge construction, the prefabricated segmental cantilever assembly process has been widely used due to its advantages of low environmental impact, reliable quality, fast construction speed and short construction period. The prefabricated section cantilever assembly process is to divide the main girder of the bridge into several sections for prefabrication, and then transport them to the construction site for splicing. See Figure 1. After the T-shaped structure formed by the
预制节段悬臂拼装工艺又分为对称拼装工艺和非对称拼装工艺,在实际施工中通常使用的是对称拼装工艺,但是在经过一些特殊地形如铁路、河流等,则需要采用非对称拼装工艺,悬臂梁在非对称拼装工艺施工过程中所受到的非对称力远大于采用对称拼装工艺所受到的非对称力,因此,在非对称拼装工艺施工过程中,如何保证非对称受力悬臂梁的平衡是施工成功的关键所在。The cantilever assembly process of prefabricated segments is divided into symmetrical assembly process and asymmetrical assembly process. Symmetrical assembly process is usually used in actual construction, but asymmetrical assembly process is required when passing through some special terrains such as railways and rivers. The asymmetric force suffered by the cantilever beam during the construction process of the asymmetric assembly process is much greater than that received by the symmetrical assembly process. Therefore, in the construction process of the asymmetric assembly process, how to ensure the balance of the asymmetrically stressed cantilever beam is the construction The key to success.
专利文件ZL201811549814.5公开了一种架桥机悬臂拼装施工方法,该方法本质上是一种“非对称受力悬臂拼装方法”,为了平衡T构两侧的受力,在始发块两侧下方设置抗拉束,并且在始发块一侧下方设置有轴力自动伺服系统,通过所述抗拉束施加在所述始发块两侧的拉力调整和所述轴力自动伺服系统施加在所述始发块一侧的反顶力调整,以此平衡所述悬臂梁两侧的受力;专利文件ZL201811554818.2中,对应用“非对称受力悬臂拼装方法”时利用抗拉束与轴力伺服系统来保证T形结构两侧的平衡提出具体的应用思路。但是,在实际工程应用中,采用的悬臂梁平衡装置结构复杂,需要抗拉束和轴力伺服系统一起配合才能完成对悬臂梁的平衡,然而轴力伺服系统使用的加载与卸载需要与作业工序密切结合、穿插进行,导致作业工况的控制步骤十分复杂,控制难度大大提高,给工程的安全控制带来不可控的风险,降低了施工效率。Patent document ZL201811549814.5 discloses a construction method for cantilever assembly of a bridge erecting machine, which is essentially an "asymmetrically stressed cantilever assembly method". In order to balance the force on both sides of the T structure, Tensile beams are arranged below, and an axial force automatic servo system is arranged under one side of the originating block, and the tensile force applied on both sides of the originating block by the tension beams is adjusted and the axial force automatic servo system is applied on the The anti-jacking force on one side of the starting block is adjusted to balance the force on both sides of the cantilever beam; Axial force servo system to ensure the balance on both sides of the T-shaped structure puts forward specific application ideas. However, in practical engineering applications, the structure of the cantilever beam balancing device used is complex, and the tension beam and the axial force servo system must cooperate to complete the balance of the cantilever beam. The close combination and interspersed operation lead to very complicated control steps of the operating conditions, which greatly increases the difficulty of control, brings uncontrollable risks to the safety control of the project, and reduces the construction efficiency.
发明内容Contents of the invention
本发明的目的在于提供一种非对称受力悬臂梁的平衡装置,以解决桥梁建造用到轴力伺服系统时控制步骤复杂,控制难度高的问题。The purpose of the present invention is to provide a balance device for an asymmetrically stressed cantilever beam to solve the problem of complicated control steps and high control difficulty when an axial force servo system is used in bridge construction.
为达此目的,本发明采用以下技术方案:For reaching this purpose, the present invention adopts following technical scheme:
一种非对称受力悬臂梁的平衡装置,其特征在于,包括压力检测装置、张拉装置和控制装置,所述压力检测装置设置在吊装设备的支腿与悬臂梁之间,所述控制装置能够接收所述压力检测装置的传输信号,所述张拉装置包括:A balance device for an asymmetrically stressed cantilever beam, characterized in that it includes a pressure detection device, a tension device and a control device, the pressure detection device is arranged between the legs of the hoisting equipment and the cantilever beam, and the control device Capable of receiving the transmission signal of the pressure detection device, the tension device includes:
抗拉束,包括钢丝和张拉杆,所述钢丝的底端与地基固定连接,所述张拉杆与所述钢丝的顶端固定连接,所述张拉杆的顶端穿过所述悬臂梁并螺纹连接有锚圈,所述抗拉束的拉力能够通过所述锚圈传递至所述悬臂梁;Tensile beams, including steel wires and tension rods, the bottom ends of the steel wires are fixedly connected to the foundation, the tension rods are fixedly connected to the top ends of the steel wires, and the top ends of the tension rods pass through the cantilever beams and are screwed to An anchor ring, the tensile force of the tensile beam can be transmitted to the cantilever beam through the anchor ring;
张拉机构,与所述张拉杆连接,所述张拉机构包括支座以及与所述支座连接的千斤顶、螺母组件和拧紧组件,所述支座与所述悬臂梁固定连接,所述螺母组件的螺母与所述张拉杆的上部螺纹连接,所述千斤顶设置在所述支座和所述螺母组件之间且所述千斤顶能够向上顶升所述螺母以对所述抗拉束施加拉力,所述抗拉束的拉力能够通过所述支座传递至所述悬臂梁,所述拧紧组件能够带动所述锚圈沿所述张拉杆向下移动以拧紧所述锚圈;The tensioning mechanism is connected with the tensioning rod, the tensioning mechanism includes a support, a jack connected to the support, a nut assembly and a tightening assembly, the support is fixedly connected with the cantilever beam, and the nut The nut of the assembly is threadedly connected to the upper part of the tension rod, the jack is arranged between the support and the nut assembly and the jack can lift the nut upwards to apply tension to the tension beam, The tensile force of the tensile beam can be transmitted to the cantilever beam through the support, and the tightening assembly can drive the anchor ring to move down the tension rod to tighten the anchor ring;
索力动测仪,与所述抗拉束连接,用于检测所述抗拉束所施加的拉力。The cable force dynamic tester is connected with the tension beam and is used to detect the tension exerted by the tension beam.
作为优选地,所述拧紧组件包括连动杆,所述连动杆包括固定杆和与所述固定杆滑动连接的滑动杆,所述滑动杆与所述锚圈连接,所述锚圈向上移动能够推动所述滑动杆相对于所述固定杆缩进。Preferably, the tightening assembly includes a linkage rod, the linkage rod includes a fixed rod and a sliding rod slidingly connected with the fixed rod, the sliding rod is connected with the anchor ring, and the anchor ring moves upward The sliding rod can be pushed to retract relative to the fixed rod.
作为优选地,所述滑动杆的底端设置有第一齿轮,所述锚圈的外周设置有第二齿轮,所述锚圈的上端和下端均设置有齿轮限位板,所述第二齿轮设置在两个所述齿轮限位板之间,所述第一齿轮与所述第二齿轮啮合。Preferably, the bottom end of the sliding rod is provided with a first gear, the outer circumference of the anchor ring is provided with a second gear, the upper end and the lower end of the anchor ring are provided with a gear limiting plate, and the second gear It is arranged between the two gear limiting plates, and the first gear meshes with the second gear.
作为优选地,所述连动杆还包括与所述固定杆连接的丝杆,所述丝杆穿设于所述固定杆且两者之间通过单向轴承连接,所述丝杆能够绕自身轴线转动且能够上下移动以带动所述固定杆运动。Preferably, the linkage rod further includes a threaded rod connected to the fixed rod, the threaded rod passes through the fixed rod and is connected by a one-way bearing between the two, and the threaded rod can wind around itself The axis rotates and can move up and down to drive the fixed rod to move.
作为优选地,所述丝杆上设置有限位螺母和凸键滚轮,所述限位螺母与所述丝杆螺纹连接,所述限位螺母与所述支座固定连接,所述丝杆的外周面设置有凹槽,所述凹槽平行于所述丝杆的轴向延伸,所述凸键滚轮的内壁上设置有凸键,所述凸键与所述凹槽滑动连接。Preferably, a limit nut and a convex key roller are arranged on the screw rod, the limit nut is threadedly connected with the screw rod, the limit nut is fixedly connected with the support, and the outer circumference of the screw rod A groove is arranged on the surface, and the groove extends parallel to the axial direction of the screw rod. A convex key is arranged on the inner wall of the convex key roller, and the convex key is slidably connected with the groove.
作为优选地,所述拧紧组件还包括第一电机,所述第一电机与所述凸键滚轮通过皮带连接,所述第一电机能够驱动所述凸键滚轮绕所述丝杆的轴线旋转。Preferably, the tightening assembly further includes a first motor, the first motor is connected to the cam roller through a belt, and the first motor can drive the cam roller to rotate around the axis of the screw rod.
作为优选地,所述固定杆上设置有多个滑动槽,所述滑动杆上设置有多个卡柱,所述卡柱与所述滑动槽滑动配合。Preferably, the fixing rod is provided with a plurality of sliding grooves, the sliding rod is provided with a plurality of clamping posts, and the clamping posts are slidably fitted with the sliding grooves.
作为优选地,其特征在于,所述拧紧组件设置有至少两个,至少两个所述拧紧组件绕所述锚圈的外周均匀间隔排布。Preferably, it is characterized in that at least two tightening assemblies are provided, and at least two tightening assemblies are evenly spaced around the outer circumference of the anchor ring.
作为优选地,其特征在于,所述螺母组件还包括第二电机和螺母套筒,所述螺母套筒套设于所述螺母的外周且与所述螺母固定连接,所述第二电机能够驱动所述螺母套筒绕所述螺母的轴线旋转。Preferably, the nut assembly further includes a second motor and a nut sleeve, the nut sleeve is sleeved on the outer periphery of the nut and fixedly connected with the nut, and the second motor can drive The nut sleeve rotates about the axis of the nut.
本发明的目的在于提供一种非对称受力悬臂梁的平衡方法,以解决桥梁建造用到轴力伺服系统时控制步骤复杂,控制难度高的问题。The purpose of the present invention is to provide a method for balancing an asymmetrically stressed cantilever beam, so as to solve the problem of complicated control steps and high control difficulty when an axial force servo system is used in bridge construction.
为达此目的,本发明采用以下技术方案:For reaching this purpose, the present invention adopts following technical scheme:
一种非对称受力悬臂梁的平衡方法,采用如上所述的非对称受力悬臂梁的平衡装置,包括:A method for balancing an asymmetrically stressed cantilever beam, using the balance device for an asymmetrically stressed cantilever beam as described above, comprising:
步骤1:通过压力检测装置实时检测悬臂梁在支腿处的压力值,记为不平衡力,压力检测装置将不平衡力传输至控制装置;Step 1: The pressure value of the cantilever beam at the leg is detected in real time by the pressure detection device, which is recorded as the unbalanced force, and the pressure detection device transmits the unbalanced force to the control device;
步骤2:控制装置根据不平衡力计算出保持悬臂梁平衡所需的平衡力,并控制张拉装置对悬臂梁施加平衡力;Step 2: The control device calculates the balance force required to keep the cantilever beam balanced according to the unbalanced force, and controls the tensioning device to apply a balance force to the cantilever beam;
在所述步骤2中,所述张拉装置对悬臂梁施加平衡力,包括:In the
步骤21:螺母组件位于第一初始位置,螺母与千斤顶的伸缩杆接触,锚圈位于第二初始位置,锚圈抵紧悬臂梁;Step 21: The nut assembly is at the first initial position, the nut is in contact with the telescopic rod of the jack, the anchor ring is at the second initial position, and the anchor ring is pressed against the cantilever beam;
步骤22:千斤顶加载,向上顶升螺母,带动螺母组件、张拉杆和锚圈同步上移第一设定距离,对钢丝施加拉力,抗拉束上的拉力通过支座作用于悬臂梁;Step 22: Load the jack, lift the nut upwards, drive the nut assembly, the tension rod and the anchor ring to move up the first set distance synchronously, apply tension to the steel wire, and the tension on the tension beam acts on the cantilever beam through the support;
步骤23:拧紧组件带动锚圈下移第一设定距离,使得锚圈回到第二初始位置;Step 23: Tighten the assembly to drive the anchor ring down the first set distance, so that the anchor ring returns to the second initial position;
步骤24:千斤顶卸压,螺母组件下移第一设定距离回到第一初始位置;Step 24: The jack releases the pressure, and the nut assembly moves down the first set distance to return to the first initial position;
步骤25:重复步骤22至24,直至索力动测仪检测到的抗拉束所施加的拉力大于等于平衡力;返回步骤1。Step 25: Repeat steps 22 to 24 until the tensile force detected by the cable force dynamic tester is greater than or equal to the balance force; return to
有益效果:Beneficial effect:
本发明提供的非对称受力悬臂梁的平衡装置,通过压力检测装置实时检测悬臂梁在支腿处的不平衡力,控制装置会根据不平衡力计算出保持悬臂梁平衡所需的平衡力,并控制张拉装置对悬臂梁施加平衡力,直至索力动测仪测出的拉力大于等于平衡力即停止张拉。当不平衡力发生变化时,控制装置会重新计算平衡力并使张拉装置对悬臂梁继续施加平衡力,实现对悬臂梁的实时平衡。The balance device of the asymmetrically stressed cantilever beam provided by the present invention detects the unbalanced force of the cantilever beam at the outrigger in real time through the pressure detection device, and the control device calculates the balance force required to maintain the balance of the cantilever beam according to the unbalanced force, And control the tensioning device to apply a balance force to the cantilever beam until the tension measured by the cable force dynamic tester is greater than or equal to the balance force, then stop tensioning. When the unbalanced force changes, the control device will recalculate the balanced force and make the tensioning device continue to apply a balanced force to the cantilever beam, so as to realize the real-time balance of the cantilever beam.
张拉装置中,抗拉束包括钢丝和张拉杆,钢丝的底端与地基固定,张拉杆与钢丝的顶端固定连接,张拉杆顶端穿过悬臂梁并螺纹连接有锚圈,使抗拉束能够对悬臂梁施加拉力,在张拉前,螺母组件在第一初始位置,锚圈位于第二初始位置,在张拉时,千斤顶、锚圈和螺母组件同时向上移动第一设定距离对抗拉束施加拉力,抗拉束的拉力通过支座传递至所述悬臂梁,完成一次张拉后,拧紧组件使锚圈下移第一设定距离回到第二初始位置,以固定张拉后的抗拉束,抗拉束的拉力通过锚圈传递至所述悬臂梁千斤顶泄压,螺母组件下移第一设定距离回到第一初始位置,拧紧组件复位,即可以进行下一次的张拉,因此张拉装置能够进行多次张拉,避免了使用控制十分困难的轴力伺服系统配合抗拉束才能对悬臂梁进行平衡,减少了施工成本,降低了工程作业的控制难度,保证了施工安全,大大提高了施工效率。In the tensioning device, the tension beam includes steel wire and tension rod, the bottom end of the steel wire is fixed to the foundation, the tension rod is fixedly connected to the top end of the steel wire, and the top end of the tension rod passes through the cantilever beam and is screwed with an anchor ring, so that the tension beam can be Apply tension to the cantilever beam. Before tensioning, the nut assembly is at the first initial position, and the anchor ring is at the second initial position. When tensioning, the jack, anchor ring, and nut assembly simultaneously move up the first set distance to resist the tension beam Applying tension, the tensile force of the tensile beam is transmitted to the cantilever beam through the support. After a tension is completed, the assembly is tightened to move the anchor ring down the first set distance and return to the second initial position, so as to fix the tensile force. Pull the beam, the tensile force of the tensile beam is transmitted to the cantilever beam jack through the anchor ring to release the pressure, the nut assembly moves down the first set distance and returns to the first initial position, and the tightening assembly resets, that is, the next tensioning can be carried out. Therefore, the tensioning device can perform multiple tensions, avoiding the use of the axial force servo system, which is very difficult to control, and the tension beam to balance the cantilever beam, reducing the construction cost, reducing the control difficulty of engineering operations, and ensuring construction safety. , greatly improving the construction efficiency.
附图说明Description of drawings
图1是现有的桥梁预制节段悬臂拼装的示意图;Fig. 1 is the schematic diagram of existing bridge prefabricated section cantilever assembly;
图2是本发明实施例提供的非对称受力悬臂梁的平衡装置在使用时的示意图;Fig. 2 is a schematic diagram of the balance device of the asymmetrically stressed cantilever beam provided by the embodiment of the present invention in use;
图3是本发明实施例提供的张拉机构的示意图一,此时螺母组件处于第一初始位置,锚圈处于第二初始位置;Fig. 3 is a schematic diagram 1 of the tensioning mechanism provided by the embodiment of the present invention, at this moment, the nut assembly is in the first initial position, and the anchor ring is in the second initial position;
图4是本发明实施例提供的张拉机构的示意图二,此时螺母组件和锚圈同时上移第一设定距离;Fig. 4 is a schematic diagram 2 of the tensioning mechanism provided by the embodiment of the present invention, at this time, the nut assembly and the anchor ring move up the first set distance at the same time;
图5是本发明实施例提供的张拉机构的示意图三,此时锚圈下移第一设定距离回到第二初始位置;Fig. 5 is a schematic diagram 3 of the tensioning mechanism provided by the embodiment of the present invention. At this time, the anchor ring moves down the first set distance and returns to the second initial position;
图6是本发明实施例提供的张拉机构的示意图四,千斤顶泄压;Fig. 6 is a schematic diagram 4 of the tensioning mechanism provided by the embodiment of the present invention, the jack releases pressure;
图7是本发明实施例提供的张拉机构的示意图五,螺母组件下移第一设定距离回到第一初始位置;Fig. 7 is a schematic diagram 5 of the tensioning mechanism provided by the embodiment of the present invention, the nut assembly moves down a first set distance and returns to the first initial position;
图8是本发明实施例提供的张拉机构的示意图六,此时固定杆和丝杆上移第一设定距离;Fig. 8 is a schematic diagram 6 of the tensioning mechanism provided by the embodiment of the present invention, at this time, the fixed rod and the screw rod are moved up by the first set distance;
图9是本发明实施例提供的拧紧组件与锚圈配合的示意图;Fig. 9 is a schematic diagram of the cooperation between the tightening assembly provided by the embodiment of the present invention and the anchor ring;
图10是本发明实施例提供的固定杆的侧视图;Fig. 10 is a side view of the fixing rod provided by the embodiment of the present invention;
图11是本发明实施例提供的固定杆和滑动杆的配合示意图;Fig. 11 is a schematic diagram of cooperation between the fixed bar and the sliding bar provided by the embodiment of the present invention;
图12是本发明实施例提供的锚圈的剖面图;Fig. 12 is a sectional view of the anchor ring provided by the embodiment of the present invention;
图13是本发明实施例提供的限位螺母的俯视图;Fig. 13 is a top view of a stop nut provided by an embodiment of the present invention;
图14是本发明实施例提供的丝杆的俯视图;Fig. 14 is a top view of the screw provided by the embodiment of the present invention;
图15是本发明实施例提供的丝杆与固定杆连接处的剖面图;Fig. 15 is a cross-sectional view of the connection between the screw rod and the fixed rod provided by the embodiment of the present invention;
图16是本发明实施例提供的凸键滚轮的俯视图;Fig. 16 is a top view of the convex key roller provided by the embodiment of the present invention;
图17是本发明实施例提供的螺母组件的剖面图;Fig. 17 is a sectional view of a nut assembly provided by an embodiment of the present invention;
图18是悬臂梁受力示意图一;Fig. 18 is a schematic diagram of cantilever beam stress one;
图19是悬臂梁受力示意图二。Figure 19 is the second schematic diagram of the force on the cantilever beam.
图中:In the picture:
100-吊装设备;101-支腿;200-桥墩结构;300-始发块;100-hoisting equipment; 101-outrigger; 200-pier structure; 300-starting block;
1-张拉装置;1- tensioning device;
11-抗拉束;111-钢丝;112-张拉杆;113-锚圈;1131-齿轮限位板;11-tension beam; 111-steel wire; 112-tension rod; 113-anchor ring; 1131-gear limit plate;
12-张拉机构;12-tension mechanism;
121-千斤顶;121 - Jack;
122-螺母组件;1221-螺母;1222-第二电机;1223-螺母套筒;122-nut assembly; 1221-nut; 1222-second motor; 1223-nut sleeve;
123-拧紧组件;1231-丝杆;1232-固定杆;1233-滑动杆;1234-限位螺母;1235-凸键滚轮;1236-第一电机;1237-单向轴承;123-tightening assembly; 1231-screw; 1232-fixed rod; 1233-sliding rod; 1234-limit nut; 1235-convex key roller; 1236-first motor;
13-索力动测仪;13-Cable dynamic tester;
2-压力检测装置。2- Pressure detection device.
具体实施方式Detailed ways
下面结合附图和实施例对本发明作进一步的详细说明。可以理解的是,此处所描述的具体实施例仅仅用于解释本发明,而非对本发明的限定。另外还需要说明的是,为了便于描述,附图中仅示出了与本发明相关的部分而非全部结构。The present invention will be further described in detail below in conjunction with the accompanying drawings and embodiments. It should be understood that the specific embodiments described here are only used to explain the present invention, but not to limit the present invention. In addition, it should be noted that, for the convenience of description, only some structures related to the present invention are shown in the drawings but not all structures.
在本发明的描述中,除非另有明确的规定和限定,术语“相连”、“连接”、“固定”应做广义理解,例如,可以是固定连接,也可以是可拆卸连接,或成一体;可以是机械连接,也可以是电连接;可以是直接相连,也可以通过中间媒介间接相连,可以是两个元件内部的连通或两个元件的相互作用关系。对于本领域的普通技术人员而言,可以具体情况理解上述术语在本发明中的具体含义。In the description of the present invention, unless otherwise clearly specified and limited, the terms "connected", "connected" and "fixed" should be understood in a broad sense, for example, it can be a fixed connection, a detachable connection, or an integrated ; It can be a mechanical connection or an electrical connection; it can be a direct connection or an indirect connection through an intermediary, and it can be the internal communication of two components or the interaction relationship between two components. Those of ordinary skill in the art can understand the specific meanings of the above terms in the present invention in specific situations.
在本发明中,除非另有明确的规定和限定,第一特征在第二特征之“上”或之“下”可以包括第一和第二特征直接接触,也可以包括第一和第二特征不是直接接触而是通过它们之间的另外的特征接触。而且,第一特征在第二特征“之上”、“上方”和“上面”包括第一特征在第二特征正上方和斜上方,或仅仅表示第一特征水平高度高于第二特征。第一特征在第二特征“之下”、“下方”和“下面”包括第一特征在第二特征正下方和斜下方,或仅仅表示第一特征水平高度小于第二特征。In the present invention, unless otherwise clearly specified and limited, a first feature being "on" or "under" a second feature may include direct contact between the first and second features, and may also include the first and second features Not in direct contact but through another characteristic contact between them. Moreover, "above", "above" and "above" the first feature on the second feature include that the first feature is directly above and obliquely above the second feature, or simply means that the first feature is horizontally higher than the second feature. "Below", "beneath" and "under" the first feature to the second feature include that the first feature is directly below and obliquely below the second feature, or simply means that the first feature has a lower level than the second feature.
在本实施例的描述中,术语“上”、“下”、“右”、等方位或位置关系为基于附图所示的方位或位置关系,仅是为了便于描述和简化操作,而不是指示或暗示所指的装置或元件必须具有特定的方位、以特定的方位构造和操作,因此不能理解为对本发明的限制。此外,术语“第一”、“第二”仅仅用于在描述上加以区分,并没有特殊的含义。In the description of this embodiment, the terms "up", "down", "right", and other orientations or positional relationships are based on the orientations or positional relationships shown in the drawings, and are only for the convenience of description and simplification of operations, rather than indicating Or imply that the device or element referred to must have a specific orientation, be constructed and operate in a specific orientation, and therefore should not be construed as limiting the invention. In addition, the terms "first" and "second" are only used to distinguish in description, and have no special meaning.
下面结合附图并通过具体实施方式来进一步说明本发明的技术方案。The technical solutions of the present invention will be further described below in conjunction with the accompanying drawings and through specific implementation methods.
参见图2,本发明实施例提供一种非对称受力悬臂梁的平衡装置,包括压力检测装置2、张拉装置1和控制装置,压力检测装置2设置在吊装设备100的支腿101与悬臂梁之间,控制装置能够接收压力检测装置2的传输信号,并能够使张拉装置1对悬臂梁施加拉力,张拉装置1包括抗拉束11、张拉机构12和索力动测仪13,张拉机构12能使抗拉束11进行张拉,索力动测仪13能够检测出抗拉束11所施加的拉力。Referring to Fig. 2 , an embodiment of the present invention provides a balance device for an asymmetrically stressed cantilever beam, including a
具体地,控制装置包括第一控制装置和第二控制装置,第一控制装置设置在地面上,第一控制装置与压力检测装置2无线连接,且第一控制装置和第二控制装置无线连接,第二控制装置设置在悬臂梁上,第二控制装置与张拉装置1电连接,第一控制装置能够接收压力检测装置2发送的传输信号并计算出能够平衡悬臂梁的平衡力并上传至第二控制装置,第二控制装置能够根据第一控制装置上传的数据控制张拉装置1进行张拉,使张拉装置1对悬臂梁进行平衡。Specifically, the control device includes a first control device and a second control device, the first control device is arranged on the ground, the first control device is wirelessly connected to the
抗拉束11包括钢丝111和张拉杆112,钢丝111的底端与地基固定连接,张拉杆112与钢丝111的顶端固定连接,张拉机构12与张拉杆112连接,张拉机构12通过对张拉杆112的位置进行改变进而对抗拉束11进行张拉,且与张拉杆112连接能够使张拉机构12的部件不会因为直接和钢丝111连接而产生损坏,张拉杆112的顶端穿过悬臂梁并螺纹连接有锚圈113,当锚圈113与嵌在悬臂梁表面的锚垫板抵接时,锚圈113能够将被拉伸的钢丝111固定在当前位置而不回缩,使钢丝111对悬臂梁施加拉力。当张拉机构12对抗拉束11的顶端进行张拉时,由于抗拉束11底端固定,抗拉束11被拉长使抗拉束11能够向悬臂梁施加拉力;索力动测仪13与抗拉束11连接,索力动测仪13能够检测抗拉束11施加的拉力是否能够平衡悬臂梁。
参见图3,张拉机构12包括支座以及与支座连接的千斤顶121、螺母组件122和拧紧组件123,支座与悬臂梁固定连接,支座用于固定千斤顶121、螺母组件122和拧紧组件123,并为千斤顶121、螺母组件122和拧紧组件123提供工作空间,螺母组件122的螺母1221与张拉杆112的上部螺纹连接,千斤顶121设置在支座和螺母组件122之间且千斤顶121能够向上顶升螺母1221以对抗拉束11施加拉力,抗拉束11的拉力通过支座传递至悬臂梁,拧紧组件123能够带动锚圈113沿张拉杆112向下移动以拧紧锚圈113,通过千斤顶121、螺母组件122和拧紧组件123能够完成对抗拉束11的多次拉伸。Referring to Fig. 3, the
具体的张拉过程如下:The specific stretching process is as follows:
参见图3,在张拉前,螺母1221位于第一初始位置,螺母1221与千斤顶121的伸缩杆抵接;锚圈113位于第二初始位置,锚圈113与锚垫板抵接,进而抵紧悬臂梁。参见图4,在张拉时,千斤顶121加载,向上顶升螺母1221,进而带动螺母组件122、张拉杆112和锚圈113同步上移第一设定距离,此时抗拉束11处在被张拉的状态,抗拉束11的拉力通过螺母1221和千斤顶121最后由支座传递到悬臂梁上。参见图5,拧紧组件123启动使锚圈113下移第一设定距离,使锚圈113拧紧至与锚垫板抵接,锚圈113回到第二初始位置,此时抗拉束11的拉力通过锚圈113和锚垫板传递到悬臂梁上。参见图6,千斤顶121泄压,千斤顶121的伸缩杆下移第一设定距离;此时,由于锚圈113已经回到第二初始位置,锚圈113紧紧抵接锚垫板,使抗拉束11位置固定,即使千斤顶121泄压也不会使抗拉束11失去对悬臂梁的拉力。参见图7,螺母组件122启动,使螺母组件122沿张拉杆112下移第一设定距离直至螺母1221与千斤顶121的伸缩杆接触,此时螺母组件122回到第一初始位置。参见图8,拧紧组件123复位,当拧紧组件123复位完毕,此时可以进行下一次的张拉。Referring to Fig. 3, before tensioning, the
通过反复进行上述张拉过程,使抗拉束11能够进行多次张拉,以对抗悬臂梁上不停变化的不平衡力,避免了使用操作复杂的轴力伺服系统,提高了施工效率。By repeating the above stretching process, the
在张拉过程中,拧紧组件123能够带动锚圈113沿张拉杆112向下移动以拧紧锚圈113,同时在锚圈113随着千斤顶121上移时拧紧组件123不会干涉锚圈113。During the tensioning process, the tightening
参见图9,拧紧组件123包括连动杆,连动杆包括固定杆1232和与固定杆1232滑动连接的滑动杆1233,滑动杆1233与锚圈113连接,固定杆1232内部设置有容置腔,滑动杆1233的一端插入容置腔内。一方面,当锚圈113在千斤顶121的作用下向上移动时能够推动滑动杆1233相对于固定杆1232缩进,滑动杆1233会进入固定杆1232内部的容置腔中,因此拧紧组件123不会干涉锚圈113上移;另一方面,固定杆1232能够绕自身轴线转动且能够上下移动,同时带动滑动杆1233绕自身轴线转动。Referring to Fig. 9, the tightening
具体参见图10和图11,固定杆1232上设置有多个滑动槽,滑动槽沿固定杆1232的轴向延伸,滑动杆1233上设置有多个卡柱,卡柱与滑动槽滑动配合,当固定杆1232绕自身轴线转动时,滑动杆1233的卡柱与固定杆1232滑动槽的槽壁抵接,卡柱在固定杆1232的带动下使滑动杆1233同时旋转。Referring to Figure 10 and Figure 11 specifically, the fixed
在此对滑动槽和卡柱的数量不做限制,在本实施例中具体设置为两个滑动槽和两个卡柱,两个滑动槽在固定杆1232表面绕固定杆1232轴线均匀分布,两个卡柱在滑动杆1233顶端绕滑动杆1233的轴线均匀分布,使卡柱和滑动槽的配合更加稳固,避免出现不平衡,减少在旋转过程中的磨损。There is no limit to the number of sliding grooves and clamping columns. In this embodiment, two sliding grooves and two clamping columns are specifically arranged. The two sliding grooves are evenly distributed on the surface of the fixing
参见图9和图12,滑动杆1233的底端设置有第一齿轮,锚圈113的外周设置有第二齿轮,第一齿轮的齿和第二齿轮的齿大小相同,锚圈113的上端和下端均设置有齿轮限位板1131,第二齿轮设置在两个齿轮限位板1131之间,第一齿轮与第二齿轮啮合时,第一齿轮也处在两个齿轮限位板1131之间,当锚圈113在千斤顶121的作用下向上移动,锚圈113下端的齿轮限位板1131会与第一齿轮抵接,从而带动第一齿轮以及滑动杆1233向上移动。Referring to Fig. 9 and Fig. 12, the bottom end of sliding
参见图13和图14,连动杆还包括与固定杆1232连接的丝杆1231,丝杆1231穿设于固定杆1232且两者之间通过单向轴承1237连接,丝杆1231能够绕自身轴线转动且能够上下移动以带动固定杆1232运动,通过丝杆1231的转动和上下移动,完成对锚圈113的拧紧动作。Referring to Figure 13 and Figure 14, the linkage rod also includes a
具体地,参见图15,丝杆1231的底端设置有连接轴,连接轴与单向轴承1237的内圈连接,固定杆1232的顶端设置有转动孔,转动孔的侧壁与单向轴承1237的外圈连接。Specifically, referring to FIG. 15 , the bottom end of the
丝杆1231上设置有限位螺母1234和凸键滚轮1235,限位螺母1234与丝杆1231螺纹连接,限位螺母1234与支座固定连接,由于限位螺母1234与支座固定连接且与丝杆1231螺纹连接,当丝杆1231发生转动时,丝杆1231转动的同时会上下移动;丝杆1231的外周面设置有凹槽,凹槽平行于丝杆1231的轴向延伸,参见图16,凸键滚轮1235的内壁上设置有凸键,凸键与凹槽滑动连接,同时由于凸键伸入凹槽内,当凸键滚轮1235发生转动时,凸键一侧的侧壁会与凹槽一侧的槽壁抵接,并带动丝杆1231进行转动。A
具体地,丝杆1231与限位螺母1234的螺纹配合被配置为丝杆1231绕自身轴线朝第一方向转动时,丝杆1231会同时向下移动,当丝杆1231绕自身轴线朝第二方向转动时,丝杆1231会同时向上移动;由于单向轴承1237的轴承内圈只能相对于轴承外圈朝一个方向转动,在此设置为能够沿第一方向转动,当丝杆1231朝第一方向转动时,单向轴承1237的内圈相对于外圈转动,丝杆1231朝第一方向转动且向上移动,固定杆1232不发生转动并随丝杆1231向上移动;当丝杆1231朝第二方向转动时,单向轴承1237的内圈不能相对于外圈进行转动,因此固定杆1232会被丝杆1231带动一起朝第二方向转动,固定杆1232和丝杆1231朝第二方向转动且向下移动。Specifically, the threaded cooperation between the
在此对凹槽和凸键的数量不做限制,在本实施例中具体设置为四个凹槽和四个凸键,四个凹槽沿丝杆1231轴向均匀分布,四个凸键沿凸键滚轮1235轴向在凸键滚轮1235内侧均匀分布,四个凸键和四个凹槽滑动配合,使扭矩均匀分布在四个凸键上,避免单个凸键承受扭矩过大而造成损坏。There is no limit to the number of grooves and protruding keys. In this embodiment, four grooves and four protruding keys are specifically set. The four grooves are evenly distributed along the axial direction of the
拧紧组件123还包括第一电机1236,第一电机1236与凸键滚轮1235通过皮带连接,第一电机1236能够驱动凸键滚轮1235绕丝杆1231的轴线旋转,通过改变第一电机1236的转动方向使凸键滚轮1235能够带动丝杆1231朝第一方向或第二方向旋转,由于丝杆1231和限位螺母1234为螺纹配合,因此当丝杆1231绕自身轴线转动时会同时向上或向下移动。The tightening
进一步地,为防止第一电机1236带动丝杆1231朝第一方向旋转且向上移动的运动超出允许范围,第一电机1236上设置有旋转编码器,旋转编码器设有旋转预设值,预先计算出使丝杆1231和固定杆1232上移第一设定距离所需要的旋转预设值,当丝杆1231上移第一设定距离时旋转编码器刚好检测到第一电机1236达到旋转预设值,此时电机停止转动,避免丝杆1231运动超范围而损坏零件。Further, in order to prevent the
进一步地,第一电机1236还设置有第一扭矩限制器,第一扭矩限制器被设定有第一扭矩安全值,通过预先计算或者采用电子扭矩扳手测量出正常拧动锚圈113贴紧锚垫板时所需的扭矩值,并将该数值作为扭矩限制器的第一扭矩安全值,当拧紧组件123在第一电机1236的作用下向下移动直至锚圈113紧紧抵接锚垫板无法继续下移,此时作用在第一电机1236上的扭矩逐渐增大,当该扭矩等于第一扭矩安全值时第一扭矩限制器会使第一电机1236停止工作,拧紧组件123停止下移,防止第一电机1236和其他部件因停止不及时而造成损坏。Further, the
参见图17,螺母组件122还包括第二电机1222和螺母套筒1223,螺母套筒1223套设于螺母1221的外周且与螺母1221固定连接,第二电机1222与螺母套筒1223连接,第二电机1222能够驱动螺母套筒1223绕螺母1221的轴线旋转,由于螺母1221与张拉杆112螺纹连接,当螺母套筒1223旋转时会带动螺母1221一起向下移动至第一初始位置,完成对螺母组件122的移动。17, the
进一步地,在第二电机1222上设置有第二扭矩限制器,第二扭矩限制器被设定有第二扭矩安全值,通过预先计算或者采用电子扭矩扳手测量出正常拧动螺母1221贴紧千斤顶121端面时所需的扭矩值,并将该数值作为第二扭矩限制器的第二扭矩安全值,当螺母1221在螺母套筒1223的带动下边转动边向下移动,直至螺母1221紧贴已经泄压的千斤顶121,此时螺母1221无法继续旋转和下降,作用在第二电机1222上的扭矩越来越大,直至达到第二扭矩安全值,第二扭矩限制器启动将第二电机1222关闭,避免了对第二电机1222和螺纹的损坏。Further, a second torque limiter is provided on the
本发明实施例提供的非对称受力悬臂梁的平衡装置的大致工作过程如下:The general working process of the balance device for the asymmetrically stressed cantilever beam provided by the embodiment of the present invention is as follows:
参见图2,压力检测装置2检测到悬臂梁与支腿101之间的作用力记作不平衡力,压力检测装置2将该不平衡力上传至第一控制装置,第一控制装置根据不平衡力计算出平衡力并将平衡力上传至第二控制装置,第二控制装置根据平衡力大小控制张拉装置1进行张拉。Referring to Fig. 2, the
参见图3和图4,张拉装置1收到信号后控制千斤顶121启动,螺母组件122在千斤顶121的作用下从第一初始位置向上移动了第一设定距离,锚圈113被螺母组件122带动一起从第二初始位置向上移动第一设定距离,同时张拉杆112被带动向上移动第一设定距离使抗拉束11被张拉,此时螺母1221与顶起的千斤顶121液压杆的端面抵接,螺母1221使张拉杆112固定在被张拉后的位置,使抗拉束11在此时保持被张拉的状态,为了进行下一次的张拉,需要重复千斤顶121顶起螺母1221的过程,则需要将锚圈113下降至第二初始位置,使锚圈113重新抵接于锚垫板,以固定抗拉束11,使螺母组件122和千斤顶121能够进行复位。Referring to Fig. 3 and Fig. 4, after the
具体地,参见图9,由于第一齿轮被锚圈113周侧的齿轮限位板1131所限位,当锚圈113向上移动时,第一齿轮带动滑动杆1233一起向上移动,滑动杆1233从外部进入到固定杆1232的容置腔之中。Specifically, referring to Fig. 9, since the first gear is limited by the
参见图5和图9,拧紧机构需要将锚圈113下降至第二初始位置,第一电机1236启动,第一电机1236通过带轮和皮带带动凸键滚轮1235绕第二方向转动,由于凸键滚轮1235的凸键与丝杆1231的凹槽连接,因此凸键滚轮1235会带动丝杆1231绕第二方向转动,由于连接丝杆1231和固定杆1232的单向轴承1237的内圈相对于外圈只能朝第一方向转动,因此,丝杆1231会带动固定杆1232和滑动杆1233同步绕第二方向转动且向下移动。5 and 9, the tightening mechanism needs to lower the
滑动杆1233转动的同时,滑动杆1233下端的第一齿轮与锚圈113下端的第二齿轮啮合,因此锚圈113在滑动杆1233转动的带动下同步进行旋转,锚圈113与张拉杆112为螺纹连接,所以锚圈113在向下旋转的同时会产生沿张拉杆112轴向向下的移动,当锚圈113下降第一设定距离后,锚圈113抵接锚垫板,随着锚圈113被拧紧机构持续拧紧,作用在第一电机1236上的扭矩越来越大,当作用在第一电机1236上的扭矩等于第一扭矩安全值时,第一电机1236上设置的第一扭矩限制器启动使第一电机1236停止工作,滑动杆1233和锚圈113不再下降。When the sliding
具体地,连动杆和锚圈113被配置为转动时向下移动的速度相同,防止滑动杆1233与固定杆1232产生相对位移,影响后续丝杆1231和固定杆1232的复位动作。Specifically, the linkage rod and the
参见图6,此时锚圈113与锚垫板紧紧抵接,限制了抗拉束11的回缩,使抗拉束11固定,此时千斤顶121能够进行泄压,千斤顶121的活塞杆下移,使螺母组件122与千斤顶121分离,为了进行下一次的张拉,需要使螺母组件122下降至第一初始位置重新与千斤顶121抵接。Referring to Fig. 6, at this time, the
参见图7,螺母组件122的第二电机1222启动,使螺母套筒1223带动螺母1221绕张拉杆112轴向转动同时向下移动,当螺母组件122下降第一设定距离时,螺母1221紧贴千斤顶121活塞杆的端面,随着螺母1221被螺母套筒1223持续拧紧,作用在第二电机1222上的扭矩越来越大,当作用在第二电机1222上的扭矩等于第二扭矩安全值时,第二电机1222上设置的第二扭矩限制器启动使第二电机1237停止工作,锚圈113不再下降。Referring to Fig. 7, the
此时,螺母1221回到第一初始位置,锚圈113回到第二初始位置,由于连动杆和锚圈113在第一电机1236的作用下一起向下进行了移动,拧紧组件123中的滑动杆1233仍全部处在固定杆1232的容置腔中,又因为在对抗拉束11的拉伸中,锚圈113和滑动杆1233是被千斤顶121带动向上移动的,而固定杆1232的位置是不动的,滑动杆1233需要向上进入到固定杆1232的容置腔中,所以需要将拧紧组件123中的丝杆1231和固定杆1232上移第一设定距离到张拉前的位置,使滑动杆1233从固定杆1232容置腔中完全伸出,为下次张拉时滑动杆1233的移动提供空间。Now, the
参考图8,拧紧组件123的第一电机1236启动,第一电机1236通过第一带轮和第一皮带使凸键滚轮1235绕第一方向转动,丝杆1231在凸键滚轮1235的带动下同时绕第一方向转动且向上移动,由于单向轴承1237的内圈能够相对于外圈绕第一方向运动,因此,与单向轴承1237外圈连接的固定杆1232不会随着丝杆1231一起绕第一方向运动,但是固定杆1232会随着丝杆1231一起向上移动,当丝杆1231上移第一设定距离时旋转编码器刚好检测到第一电机1236达到旋转预设值,电机停止转动,此时滑动杆1233刚好从固定杆1232的容置腔中完全伸出。Referring to Fig. 8, the
完成上述步骤后张拉装置1完成第一次张拉,此时索力动测仪13会对抗拉束11上的索力进行检测,如果索力小于平衡力,则此时抗拉束11无法提供足够的索力来平衡悬臂梁,第二控制装置会使张拉机构12进行下一次的张拉,直至索力动测仪13检测出的索力大于等于平衡力,张拉机构12才会停止张拉。当不平衡力发生变化时,第一控制装置会重新计算平衡悬臂梁所需的平衡力,然后重复上述的张拉过程,直至索力动测仪13检测出抗拉束11上的索力大于等于新的平衡力。After completing the above steps, the
本发明实施例还提供一种非对称受力悬臂梁的平衡方法,采用非对称受力悬臂梁的平衡装置完成,包括:The embodiment of the present invention also provides a method for balancing an asymmetrically stressed cantilever beam, which is completed by using a balancing device for an asymmetrically stressed cantilever beam, including:
步骤1:通过压力检测装置2实时检测悬臂梁在支腿101处的压力值,记为不平衡力,压力检测装置2将不平衡力传输至控制装置;Step 1: The pressure value of the cantilever beam at the
步骤2:控制装置根据不平衡力计算出保持悬臂梁平衡所需的平衡力,并控制张拉装置1对悬臂梁施加平衡力。Step 2: The control device calculates the balance force required to keep the cantilever beam balanced according to the unbalanced force, and controls the
由于张拉装置1对抗拉束11的一次张拉很难使抗拉束11上索力达到平衡力,因此需要张拉装置1对抗拉束11进行多次的张拉,直至抗拉束11上的索力大于等于平衡力即停止张拉,当不平衡力发生变化时,控制装置会根据不断变化了不平衡力控制张拉机构12实时地进行多次张拉,避免了使用操作复杂的轴力伺服系统,降低了工程难度,增加了工作效率。Since the
在步骤1中,通过在悬臂梁与支腿101间设置压力检测装置2,能够对悬臂梁在支腿101处的压力进行实时的检测,压力检测装置2将不平衡力传输至第一控制装置,第一控制装置接收到压力检测装置2的传输信号,计算出能够平衡悬臂梁的平衡力并上传至第二控制装置。In
步骤2中包括:
步骤21:螺母组件122位于第一初始位置,锚圈113位于第二初始位置。Step 21: The
参见图2,压力检测装置2检测到悬臂梁与支腿101之间的作用力记作不平衡力,压力检测装置2将该不平衡力上传至第一控制装置,第一控制装置根据不平衡力计算出平衡力并将平衡力上传至第二控制装置,第二控制装置根据平衡力大小控制张拉装置1进行张拉。Referring to Fig. 2, the
步骤22:千斤顶121加载,带动螺母组件122、张拉杆112和锚圈113同步上移第一设定距离,对钢丝111施加拉力,抗拉束11上的拉力通过支座作用于悬臂梁。Step 22: The
参见图3和图4,张拉装置1收到信号后控制千斤顶121启动,螺母组件122在千斤顶121的作用下从第一初始位置向上移动了第一设定距离,锚圈113被螺母组件122带动一起从第二初始位置向上移动第一设定距离,同时张拉杆112被带动向上移动第一设定距离使抗拉束11被张拉,此时螺母1221与顶起的千斤顶121液压杆的端面抵接,螺母1221使张拉杆112固定在被张拉后的位置,使抗拉束11在此时保持被张拉的状态。Referring to Fig. 3 and Fig. 4, after the
具体地,由于第一齿轮被锚圈113周侧的齿轮限位板1131所限位,当锚圈113向上移动时,第一齿轮带动滑动杆1233一起向上移动,滑动杆1233从外部进入到固定杆1232的容置腔之中。Specifically, since the first gear is limited by the
为了进行下一次的张拉,需要重复千斤顶121顶起螺母1221的过程,则需要将锚圈113下降至第二初始位置,使锚圈113重新抵接于锚垫板,以固定抗拉束11,使螺母组件122和千斤顶121能够进行复位。In order to carry out the next tensioning, it is necessary to repeat the process of jacking up the
步骤23:锚圈113下移第一设定距离回到第二初始位置。Step 23: The
具体参见图5和图9,拧紧机构需要将锚圈113下降至第二初始位置,第一电机1236启动,第一电机1236通过带轮和皮带带动凸键滚轮1235绕第二方向转动,由于凸键滚轮1235的凸键与丝杆1231的凹槽连接,因此凸键滚轮1235会带动连动杆绕第二方向转动,由于连接丝杆1231和固定杆1232的单向轴承1237的内圈相对于外圈不能朝第二方向转动,因此内圈会带动外圈一起转动,丝杆1231会带动固定杆1232和滑动杆1233同步绕第二方向转动且向下移动。5 and 9, the tightening mechanism needs to lower the
滑动杆1233转动的同时,滑动杆1233下端的第一齿轮与锚圈113下端的第二齿轮啮合,因此锚圈113在滑动杆1233转动的带动下同步进行旋转,锚圈113与张拉杆112为螺纹连接,所以锚圈113在向下旋转的同时会产生沿张拉杆112轴向向下的移动,当锚圈113下降第一设定距离后,锚圈113抵接锚垫板,随着锚圈113被拧紧机构持续拧紧,作用在第一电机1237上的扭矩越来越大,当作用在第一电机1237上的扭矩等于第一扭矩安全值时,第二电机1237上设置的第一扭矩限制器启动使第二电机1237停止工作,锚圈113不再下降。When the sliding
具体地,连动杆和锚圈113被配置为转动时向下移动的速度相同,防止滑动杆1233与固定杆1232产生相对位移,避免影响后续丝杆1231和固定杆1232的复位动作。Specifically, the linkage rod and the
步骤24:千斤顶121卸压,螺母组件122下移第一设定距离回到第一初始位置;Step 24: The
参见图6锚圈113至与锚垫板紧紧抵接,限制了抗拉束11的回缩,使抗拉束11固定,此时千斤顶121泄压,千斤顶121的活塞杆下移,使螺母组件122与千斤顶121分离,为了进行下一次的张拉需要使螺母组件122下降至第一初始位置重新与千斤顶121抵接。See Figure 6 until the
参见图7,螺母组件122的第二电机1222启动,使螺母套筒1223带动螺母1221绕张拉杆轴向转动同时向下移动,当螺母组件122下降第一设定距离时,螺母1221紧贴千斤顶121活塞杆的端面,随着螺母1221被螺母套筒1223持续拧紧,作用在第二电机1222上的扭矩越来越大,当作用在第二电机1222上的扭矩等于第二扭矩安全值时,第二电机1222上设置的第二扭矩限制器启动使第二电机1237停止工作,锚圈113不再下降。Referring to Fig. 7, the
此时,螺母1221回到第一初始位置,锚圈113回到第二初始位置,由于连动杆和锚圈113在第一电机1237的作用下一起向下进行了移动,拧紧组件123中的滑动杆1233全部处在固定杆1232的容置腔中,又因为在对抗拉束11的拉伸中,锚圈113和滑动杆1233是被千斤顶121带动向上移动的,而固定杆1232的位置是不动的,滑动杆1233需要向上进入到固定杆1232的容置腔中,所以需要将拧紧组件123中的丝杆1231和固定杆1232上移第一设定距离到张拉前的位置,使滑动杆1233从固定杆1232容置腔中完全出,为下次张拉滑动杆1233的移动提供空间。At this time, the
参见图8和图9,拧紧组件第一电机启动,第一电机1236通过带轮和皮带使凸键滚轮1235绕第一方向转动,丝杆1231在凸键滚轮1235的带动下同时绕第一方向转动且向上移动,由于单向轴承1237的内圈能够相对于外圈绕第一方向运动,因此,与外圈连接的固定杆1232不会随着丝杆1231一起绕第一方向运动,但是固定杆1232会随着丝杆1231一起向上移动,当丝杆1231上移第一设定距离时旋转编码器刚好检测到第一电机1236达到旋转预设值,电机停止转动,此时滑动杆1233刚好从固定杆1232的容置腔中完全伸出。Referring to Fig. 8 and Fig. 9, the first motor of the tightening assembly is started, the
步骤25:重复步骤22至24,直至索力动测仪13检测到的抗拉束11所施加的拉力大于等于平衡力;返回步骤1。Step 25: Repeat steps 22 to 24 until the tensile force exerted by the
完成上述步骤后张拉装置1完成第一次张拉,此时索力动测仪13会对抗拉束11上的索力进行检测,如果索力小于平衡力,则此时抗拉束11无法提供足够的索力来平衡悬臂梁,第二控制装置会使张拉机构12会进行下一次的张拉,直至索力动测仪13检测出的索力大于等于平衡力,张拉机构12停止张拉。After completing the above steps, the
当不平衡力发生变化时,第一控制装置会重新计算平衡悬臂梁所需的平衡力,然后重复上述的张拉过程,直至索力动测仪13检测出抗拉束11上的索力大于等于新的平衡力。When the unbalanced force changes, the first control device will recalculate the balance force required to balance the cantilever beam, and then repeat the above-mentioned tensioning process until the cable force
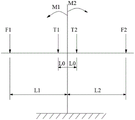
本发明实施例提供的一种非对称受力悬臂梁的平衡方法,采用非对称受力悬臂梁的平衡计算公式完成,具体参见图2、图18和图19,包括:A method for balancing an asymmetrically stressed cantilever beam provided in an embodiment of the present invention is completed by using the balance calculation formula of an asymmetrically stressed cantilever beam. Refer to Figure 2, Figure 18 and Figure 19 for details, including:
将两侧抗拉束11对悬臂梁所施加的初始索力设为T0,将左侧抗拉束11对悬臂梁所施加的力设为T1,将右侧抗拉束11对悬臂梁所施加的力设为T2,左右抗拉束11距离始发块300中心的距离均为L0,将左侧支腿101对悬臂梁所施加的力设为F1,左侧支腿101距离始发块300中心的距离为L1,将右侧支腿101对悬臂梁所施加的力设为F2,右侧支腿101距离始发块300中心的距离为L2,悬臂梁的逆时针力矩设为M1,悬臂梁的顺时针力矩设为M2。Set the initial cable force exerted by the
当悬臂梁两侧只有一个支腿101作用在悬臂梁上时,以只有左侧支腿101作用在悬臂梁上而右侧支腿101作用在另一个桥墩结构200上时为例,参见图18,由于F1作用在悬臂梁上,导致桥墩结构200和始发块300构成的T形结构具有发生逆时针倾覆的可能,因此需要右侧抗拉束11进行张拉来平衡左侧支腿101对悬臂梁所施加的力T2,使得M1=M2。When only one
按照力矩平衡原则可以建立如下计算公式:According to the principle of moment balance, the following calculation formula can be established:
M1=M2→F1×L1+T1×L0=T2×L0→T2=(F1×L1+T1×L0)÷L0M1=M2→F1×L1+T1×L0=T2×L0→T2=(F1×L1+T1×L0)÷L0
公式中F1数值由压力检测装置2检测获得,T1数值由索力动测仪13检测获得。In the formula, the value of F1 is obtained by the detection of the
此时,单根钢丝111需要张拉的索力Tn=(T2-T0)÷N,其中N为抗拉束11中钢丝111的根数。At this time, a
由于施工中还存在一些无法预料的情况,如梁段重量偏差、支腿101位置偏差、不确定的施工资源(如设备、材料、人员)分布位置等,因此设计抗拉束11的拉力时还需要考虑一定的安全系数,在此将安全系数设为K1,即能够保持悬臂梁平衡时右侧单根钢丝111的索力为K1*Tn。Because there are still some unforeseen situations in the construction, such as the weight deviation of the beam section, the position deviation of the
当悬臂梁两侧均有支腿101作用在悬臂梁上时,参见图19,按照“左侧抗拉束11负责抵抗T形结构的顺时针倾覆力矩,右侧抗拉束11负责抵抗T形结构的逆时针倾覆力矩”的原则,建立如下计算公式:When both sides of the cantilever beam have
M1=F1×L1=T2×L0→T2=F1×L1÷L0M1=F1×L1=T2×L0→T2=F1×L1÷L0
M2=F2×L2=T1×L0→T1=F2×L2÷L0M2=F2×L2=T1×L0→T1=F2×L2÷L0
公式中F1和F2的数值均由压力检测装置2测出。The values of F1 and F2 in the formula are both measured by the
此时,左侧抗拉束11的单根钢丝111所需要张拉的索力为T1n=(T2-T0)÷N,右侧抗拉束11的单根钢丝111所需要张拉的索力为T2n=(T1-T0)÷N。At this time, the cable force required by the
由于施工中还存在一些法预料的情况,如梁段重量偏差、支腿101位置偏差、不确定的施工资源(如设备、材料、人员)分布位置等,因此设计抗拉束11的拉力时还需要考虑一定的安全系数,在此将安全系数设为K2,即能够保持悬臂梁平衡时左侧抗拉束11单根钢丝111的索力为K2*T1n,能够保持悬臂梁平衡时右侧单根钢丝111的索力为K2*T2n。Since there are still some unpredictable situations in the construction, such as the weight deviation of the beam section, the position deviation of the
显然,本发明的上述实施例仅仅是为了清楚说明本发明所作的举例,而并非是对本发明的实施方式的限定。对于所属领域的普通技术人员来说,能够进行各种明显的变化、重新调整和替代而不会脱离本发明的保护范围。这里无需也无法对所有的实施方式予以穷举。凡在本发明的精神和原则之内所作的任何修改、等同替换和改进等,均应包含在本发明权利要求的保护范围之内。Apparently, the above-mentioned embodiments of the present invention are only examples for clearly illustrating the present invention, rather than limiting the implementation of the present invention. Various obvious changes, readjustments, and substitutions will occur to those skilled in the art without departing from the scope of the present invention. It is not necessary and impossible to exhaustively list all the implementation manners here. All modifications, equivalent replacements and improvements made within the spirit and principles of the present invention shall be included within the protection scope of the claims of the present invention.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202211099642.2A CN115369780B (en) | 2022-09-07 | 2022-09-07 | Balancing devices and methods for asymmetric cantilever beams |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202211099642.2A CN115369780B (en) | 2022-09-07 | 2022-09-07 | Balancing devices and methods for asymmetric cantilever beams |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN115369780A true CN115369780A (en) | 2022-11-22 |
| CN115369780B CN115369780B (en) | 2025-12-05 |
Family
ID=84072435
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202211099642.2A Active CN115369780B (en) | 2022-09-07 | 2022-09-07 | Balancing devices and methods for asymmetric cantilever beams |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN115369780B (en) |
Citations (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5241721A (en) * | 1990-10-11 | 1993-09-07 | Societe Centrale D'etudes Et De Scetauroute Realisations Routiers | Method of constructing a cable-stayed bridge composed of an assembly of voussoirs |
| CN207775734U (en) * | 2017-12-12 | 2018-08-28 | 中交第二公路工程局有限公司 | A kind of balance regulator of single-cantilever assembly |
| CN109610330A (en) * | 2018-12-18 | 2019-04-12 | 腾达建设集团股份有限公司 | A kind of Bridge Erector passing method |
| CN109610327A (en) * | 2018-12-18 | 2019-04-12 | 腾达建设集团股份有限公司 | A kind of Bridge Erector free cantilever erection construction method |
| CN109610346A (en) * | 2018-12-18 | 2019-04-12 | 腾达建设集团股份有限公司 | A kind of cantilever beam method of adjustment |
| CN111485675A (en) * | 2020-04-11 | 2020-08-04 | 吴立新 | Low-retraction prestressed anchorage device and tensioning method |
| CN213538648U (en) * | 2020-04-10 | 2021-06-25 | 中铁上海工程局集团有限公司 | A laterally unbalanced oblique pull buckle system |
| CN214459656U (en) * | 2020-12-10 | 2021-10-22 | 中铁二局第四工程有限公司 | A pull anchor bracket device |
| CN113684769A (en) * | 2021-08-03 | 2021-11-23 | 江阴法尔胜住电新材料有限公司 | Temporary buckling cable force adjusting device for construction of bilateral cantilever type main beam and using method thereof |
| WO2022116394A1 (en) * | 2020-12-04 | 2022-06-09 | 中铁北京工程局集团第二工程有限公司 | Construction method for continuous beam having asymmetrical cross section stiffened by large-span arch |
| CN114960467A (en) * | 2022-07-08 | 2022-08-30 | 腾达建设集团股份有限公司 | Cantilever beam construction method based on support leg counter-force adjustment |
| CN218436675U (en) * | 2022-09-07 | 2023-02-03 | 腾达建设集团股份有限公司 | Balance device of asymmetric stress cantilever beam |
-
2022
- 2022-09-07 CN CN202211099642.2A patent/CN115369780B/en active Active
Patent Citations (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5241721A (en) * | 1990-10-11 | 1993-09-07 | Societe Centrale D'etudes Et De Scetauroute Realisations Routiers | Method of constructing a cable-stayed bridge composed of an assembly of voussoirs |
| CN207775734U (en) * | 2017-12-12 | 2018-08-28 | 中交第二公路工程局有限公司 | A kind of balance regulator of single-cantilever assembly |
| CN109610330A (en) * | 2018-12-18 | 2019-04-12 | 腾达建设集团股份有限公司 | A kind of Bridge Erector passing method |
| CN109610327A (en) * | 2018-12-18 | 2019-04-12 | 腾达建设集团股份有限公司 | A kind of Bridge Erector free cantilever erection construction method |
| CN109610346A (en) * | 2018-12-18 | 2019-04-12 | 腾达建设集团股份有限公司 | A kind of cantilever beam method of adjustment |
| CN213538648U (en) * | 2020-04-10 | 2021-06-25 | 中铁上海工程局集团有限公司 | A laterally unbalanced oblique pull buckle system |
| CN111485675A (en) * | 2020-04-11 | 2020-08-04 | 吴立新 | Low-retraction prestressed anchorage device and tensioning method |
| WO2022116394A1 (en) * | 2020-12-04 | 2022-06-09 | 中铁北京工程局集团第二工程有限公司 | Construction method for continuous beam having asymmetrical cross section stiffened by large-span arch |
| CN214459656U (en) * | 2020-12-10 | 2021-10-22 | 中铁二局第四工程有限公司 | A pull anchor bracket device |
| CN113684769A (en) * | 2021-08-03 | 2021-11-23 | 江阴法尔胜住电新材料有限公司 | Temporary buckling cable force adjusting device for construction of bilateral cantilever type main beam and using method thereof |
| CN114960467A (en) * | 2022-07-08 | 2022-08-30 | 腾达建设集团股份有限公司 | Cantilever beam construction method based on support leg counter-force adjustment |
| CN218436675U (en) * | 2022-09-07 | 2023-02-03 | 腾达建设集团股份有限公司 | Balance device of asymmetric stress cantilever beam |
Non-Patent Citations (3)
| Title |
|---|
| 曹林祥;杜俊;张延河;李东辉;: "九江长江公路大桥塔梁临时约束设计及施工", 世界桥梁, no. 03, 28 May 2015 (2015-05-28) * |
| 赵成贵;: "商合杭铁路芜湖长江公铁大桥斜拉索安装控制技术", 桥梁建设, no. 04, 28 August 2020 (2020-08-28) * |
| 钟顺福;赵丰喜;曹明明;党权交;: "斜拉索相对拔出量控制二张索力技术研究", 世界桥梁, no. 04, 28 July 2013 (2013-07-28) * |
Also Published As
| Publication number | Publication date |
|---|---|
| CN115369780B (en) | 2025-12-05 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN101824960B (en) | Full-hydraulic screw drilling machine | |
| CN102383776B (en) | Drilling rig monitoring method, controller and system, and drilling rig | |
| KR102163658B1 (en) | Pile upending device | |
| CN105675280A (en) | Bending-torsion compound fatigue damage monitoring device and method for main shaft of thousand-meter deep well hoist | |
| CN111851320B (en) | A bridge swivel system and method based on self-adjusting support feet | |
| CN106049394B (en) | A kind of control method and control system of hydraulic bolt formula jacking equipment | |
| CN206736748U (en) | The thrustor of constructing swivel bridge | |
| CN116858679B (en) | Test apparatus and its application method for testing the mechanical properties of anchor bolts/cables under tension-shear loads | |
| CN218436675U (en) | Balance device of asymmetric stress cantilever beam | |
| CN106698148B (en) | A hoisting wire rope wire tension measuring device | |
| CN115506265B (en) | Multipoint walking pushing equipment and pushing process for large-section I-shaped steel beam | |
| CN108360820B (en) | Cable tensioning device | |
| CN216208171U (en) | Building engineering foundation pile resistance to compression static load test device | |
| CN115369780B (en) | Balancing devices and methods for asymmetric cantilever beams | |
| CN116289492B (en) | Assembled steel trestle structure and steel trestle construction method | |
| WO2012074391A1 (en) | Jacking system | |
| CN114720125B (en) | Multi-structure-size slewing bearing test bed and detection method | |
| CN217173124U (en) | Hydraulic lifting equipment and tensioning mechanism thereof | |
| CN113585104B (en) | Truss and track self-walking system of bridge construction hanging basket | |
| US20200339225A1 (en) | Chain jack | |
| CN115402944A (en) | Lifting and jacking integrated crown block system | |
| KR20220060280A (en) | Apparatus and method for testing hydraulic winches | |
| CN111877984A (en) | Pile machine | |
| CN105862938B (en) | Steel pipe inclined pile self-balancing method load box test structure and test method | |
| CN108639980B (en) | Weight limiter detection device for tower crane |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |