Automatic sorting system without manual preliminary sorting and sorting method thereof
Technical Field
The invention belongs to the technical field of sorting of materials in a bin, and particularly relates to an automatic sorting system without manual preliminary sorting and a sorting method thereof.
Background
The existing sorting scheme in the warehouse has the following flows: the truck arrives at the entrance to the warehouse and the crew unloads the goods from the truck and places them in a buffer at the entrance to the warehouse. Then, the workers carry out primary classification (generally divided into two types) according to the goods distribution area; the goods divided into two types are sequentially conveyed to the sorting line through the conveying lines to be manually packed and sorted, or are respectively conveyed to different sorting lines through two independent conveying lines to be sorted. The purpose of primary classification is to reduce the classification quantity in a sorting, reduce the number of the last grid openings of a classification of sorting machine, shorten the average stroke of the sorting trolley from the upper package to the lower package, thereby improving the working efficiency of the trolley and avoiding the situation that goods are packed again after passing through a long distance on the sorting machine.
In the process, unloading, pre-sorting and pre-sorting are carried out, then the materials are sent to a conveying line in batches, and packaging operation is carried out at a sorting line, all the operations need to be manually participated, and the labor cost required to be consumed is high; moreover, the mode that two types of roughly divided goods are firstly sent to a sorting line can cause the other type of goods to be accumulated at the entrance of the warehouse to influence the subsequent unloading operation; and the mode that two kinds of goods of rough classification sent two letter sorting lines simultaneously can avoid the problem of goods backlog, nevertheless need dispose two sets of independent transfer chain and letter sorting line, and equipment cost is higher, and is lower to the utilization ratio in warehouse space.
In addition, the upper packing table of the existing circular cross belt sorting machine is mostly arranged outside a loop line so as to facilitate workers to take goods to be sorted; however, this method results in a large amount of space inside the loop being wasted, reducing the utilization of warehouse space.
Disclosure of Invention
The invention aims to provide an automatic sorting system without manual preliminary sorting and a sorting method thereof.
The invention discloses an automatic sorting system without manual preliminary sorting, which comprises a circular cross belt sorting machine, a transfer conveyor, a feeding conveyor and an automatic pre-sorting and packaging module. The feed conveyor is used for receiving the sorted goods and conveying the goods to the transfer conveyor. The transfer conveyor is used for conveying goods to a temporary goods storage area of the automatic pre-sorting and packaging module. The annular cross belt sorting machine is divided into two sorting areas. Each sorting area comprises a feeding section and a sorting section. The automatic pre-sorting and packaging module is arranged on the inner side of the ring-shaped cross belt sorting machine.
The automatic pre-sorting and packaging module comprises a weighing and code scanning mechanism and two leading-in sections. The lateral part of sweeping yard mechanism of weighing is provided with the goods temporary storage area. The weighing and code scanning mechanism comprises a weighing and conveying mechanism, a pre-classification recognition camera and two buffer sections. The input ends of the two buffer sections are respectively butted with the two ends of the weighing and conveying mechanism. Weighing conveying mechanism can detect the goods weight of self top to can carry the goods to arbitrary one buffer segment. The pre-classification recognition camera is arranged right above the weighing and conveying mechanism and used for shooting cargoes on the weighing and conveying mechanism. Each automatic pre-sorting and packaging module corresponds to two packaging platforms. The two upper package platforms are respectively butted with the two upper package sections of the annular cross belt sorting machine. The two upper packing tables are respectively connected with the two buffer sections through the two leading-in sections.
In the working process, goods are conveyed to a temporary goods storage area of the automatic pre-sorting and packaging module through the feeding conveyor and the transfer conveyor; manually packaging the goods in the goods temporary storage area to a weighing and code scanning mechanism; the weighing and code scanning mechanism detects the weight of the goods and collects images of the goods, and after the categories of the goods are judged, the goods are conveyed to the sorting area of the annular cross belt sorting machine corresponding to the categories of the goods through the corresponding leading-in section and the corresponding upper packing table.
Preferably, the automatic pre-sorting and wrapping modules are sequentially arranged at intervals along the direction of the straight line segment of the sorting machine on the inner side of the circular cross belt sorting machine.
Preferably, each automatic pre-sorting and packing module comprises two weighing and code scanning mechanisms. Two code mechanism are swept in weighing side by side setting between two induction sections. Both sides of the automatic pre-sorting and packaging module are provided with temporary goods storage areas; two adjacent automatic pre-sorting and packing modules share one cargo temporary storage area.
Preferably, the pre-classification recognition camera is arranged on a frame of the weighing code scanning mechanism through a mounting bracket. Two installing supports are installed between two conveying mechanism that weigh.
As preferred, the letter sorting in-process, every is weighed and is swept a yard mechanism and all corresponds and set up a staff, puts the goods in the goods temporary storage area and weighs and sweep a yard mechanism. Two workers between two adjacent automatic pre-sorting and packing modules; two workers work back to back.
Preferably, a five-surface sweeping device is arranged at the joint of the upper package section and the sorting section of the unified sorting area of the annular cross belt sorting machine. The upper ladle table comprises 3-7 sections of conveying belts which are connected in series and is divided into a ladle supply input section, a plurality of sections of ladle supply acceleration sections and a ladle supply output section. The speed of the packet supply acceleration section is increased section by section; a bottom surface code scanning device is arranged at the upper bag platform. The bottom surface code scanning device is arranged at the gap between two adjacent sections of conveying belts and is arranged upwards. Five faces on sign indicating number device cooperation ring crossover area sorting machine are swept to bottom surface and equipment is swept, even the parcel takes place to roll in the automatic linking department of sorting package loading module and package loading platform in advance, still can ensure sweeping of bar code sign indicating number and can succeed. In addition, the accuracy of the five-surface scanning is improved, and if the goods are not loaded on the correct trolley, the goods can be found in time.
Preferably, the two upper package sections are respectively positioned in the middle of the two straight line sections of the circular cross belt sorting machine, and the sum of the conveying distances from the two upper package sections to the automatic pre-sorting upper package module is reduced.
Preferably, the cargo temporary storage area adopts a cargo hopper; an inclined slideway is arranged on the goods hopper; the top of the inclined ramp interfaces with the output area of the transfer conveyor. The bottom of the inclined slideway is connected with a goods storage area. The goods on the output area of the transfer conveyor are sent into a temporary goods storage area through a goods distributing mechanism; the goods distribution mechanism comprises a distribution plate and a distribution driving mechanism. The inner end of the shifting plate is rotatably connected with the rack and is positioned on one side of the output area of the transfer conveyor, which is far away from the inclined slideway. The shifting plate is driven to turn over by the distributing driving mechanism. The shifting plate is provided with two working positions; when the shifting plate is at the first working position, the shifting plate does not influence the goods conveying in the output area of the transfer conveyor; when the shifting plate is turned to a second working position, the shifting plate shifts goods conveyed on the output area of the transfer conveyor into the corresponding inclined slide way.
Preferably, photoelectric sensors are arranged at two ends above the conveying surface of the weighing and conveying mechanism; the photoelectric sensor is used for detecting the length of the goods.
Preferably, the conveying direction of the weighing conveying mechanism is perpendicular to the conveying direction of the corresponding upper package section on the annular cross belt sorting machine; the output end of the leading-in section is connected with the side part of the input end of the corresponding upper packing table; the output end of the upper bag table is connected with the side part of the upper bag section of the annular cross belt sorting machine; the conveying direction of the leading-in section and the conveying direction of the corresponding upper ladle table form an included angle theta 1 (ii) a The conveying direction of the upper package table and the corresponding upper package section on the circular cross belt sorting machine form an included angle theta 2 ;θ 1 +θ 2 =90°。
Preferably, an included angle of 50-75 degrees is formed between the conveying direction of the guide-in section and the conveying direction of the corresponding upper package platform; a blocking guide plate is arranged on the outer side of the joint of the leading-in section and the upper packing table; the blocking guide plate is V-shaped and is divided into a first guide section and a second guide section; the first guide section is flush with the edge of the guide-in section; the second guide section is aligned with the edge of the upper packing table far away from the leading-in section.
Preferably, the buffer section, the leading-in section and the packaging platform are formed by one belt conveyor or a plurality of belt conveyors in series.
Preferably, the transfer conveyors are all arranged in the warehouse and are provided with an input area close to the unloading position of the warehouse and an output area close to each automatic pre-sorting and bag-loading module.
Preferably, the infeed conveyor is mounted in the discharge position of the warehouse with the input end aligned with the truck discharge position. The output end of each of the plurality of infeed conveyors is connected to the side of the infeed area of the transfer conveyor.
The working method of the automatic sorting system without manual preliminary sorting comprises the following steps:
step one, the freight car travels to a discharging area at the entrance of the warehouse, and the staff sends the goods to the corresponding feeding conveyor.
And secondly, the goods enter one temporary goods storage area through the feeding conveyor and the transfer conveyor.
And step three, conveying the temporary goods storage area to a weighing and code scanning mechanism by a worker nearest to the temporary goods storage area.
Fourthly, detecting the weight of the goods by a weighing and conveying mechanism on the weighing and code scanning mechanism, and shooting and identifying the goods by a pre-classification identification camera; primarily classifying the goods according to the bar code information at the identification position; and then, the weighing and conveying mechanism conveys the goods to the packing tables corresponding to the types of the goods.
And step five, the goods are sent to the corresponding upper packing section on the sorting machine of the annular cross belt by the upper packing table. When the goods reach the corresponding lower package grid opening in the annular cross belt sorting machine, the goods are sent into the lower package grid opening, and the automatic sorting of the goods is completed.
The invention has the beneficial effects that:
1. the automatic pre-sorting and wrapping module automatically pre-sorts the goods after one-time manual wrapping, and respectively conveys the two kinds of goods to two mutually independent sorting areas on the annular cross belt sorting machine so as to shorten the average stroke of the trolley in one-time sorting. In the whole process, only the unloading process and the one-time packing process need to involve manual operation, so that the automation degree of sorting the material flows in the bin is greatly improved, and the labor cost is reduced.
2. The invention uses one circular cross belt sorting machine as two sorting lines, thereby greatly improving the utilization efficiency of the circular cross belt sorting machine. In addition, the automatic pre-sorting and wrapping module is arranged on the inner side of the annular cross belt sorting machine, so that the sum of the distances from the automatic pre-sorting and wrapping module to two sorting areas of the annular cross belt sorting machine is minimum, and the equipment cost of the automatic pre-sorting and wrapping module is reduced. In addition, this kind of mode make full use of the inside space of intercrossed belt sorting machine, improved the space utilization in warehouse.
3. According to the automatic pre-sorting and packing method, a plurality of automatic pre-sorting and packing modules are sequentially arranged at intervals at the inner side of a circular cross belt sorting machine, and workers are respectively arranged at two sides of each automatic pre-sorting and packing module; the back-to-back operation of workers between two adjacent automatic pre-sorting and packaging modules is realized, the operation processes are not influenced mutually, and the packaging efficiency is greatly improved. In addition, the invention directly conveys the goods to the temporary storage area at the side part of the automatic pre-sorting and wrapping module by utilizing the feeding conveyor and the transfer conveyor, so that the working personnel only need to concentrate on the wrapping operation, the operation complexity of the working personnel is reduced, and the working efficiency is improved.
4. According to the invention, the blocking guide plate is arranged on the outer side of the joint of the leading-in section and the upper packing table, so that the stability of the posture of the package in the process of transferring the package to the upper packing table is ensured, and the large deviation of the angle and the position of the package is avoided.
Drawings
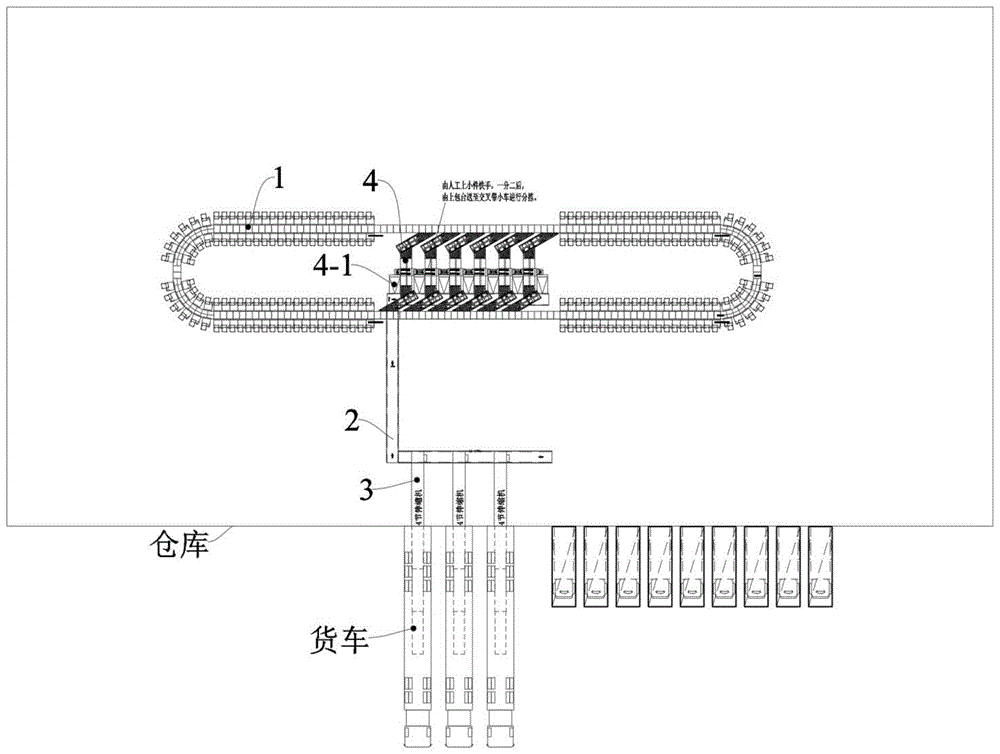
FIG. 1 is a schematic view of the overall structure of the present invention;
FIG. 2 is a schematic view of the installation of a single automated pre-sort bale-loading module within a cross-belt sorter of the present invention;
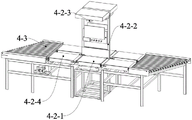
fig. 3 is a schematic structural diagram of an automatic pre-sorting and packing module according to the present invention.
Fig. 4 is a partially enlarged view of a portion a in fig. 2.
Detailed Description
The invention is further described below with reference to the accompanying drawings.
As shown in fig. 1 and 2, an automatic sorting system without manual preliminary sorting includes a cross belt sorter 1, a transfer conveyor 2, a plurality of infeed conveyors 3, and a plurality of automatic pre-sorting and bagging modules 4. The transfer conveyors 2 are all mounted in the warehouse and are provided with an input area close to the unloading position of the warehouse and an output area close to the respective pre-sorting and bagging modules 4. The plurality of feed conveyors 3 are mounted at the discharge locations of the warehouse with the input ends aligned with the plurality of truck discharge locations, respectively; the output end of each of the plurality of feed conveyors 3 is connected to the side of the input area of the transfer conveyor 2. The goods input position of each pre-sorter pick-up module 4 is located at the side of the output area of the transfer conveyor 2. The transfer conveyor 2 is used for automatically transferring the goods sent into the input area by the plurality of feeding conveyors 3 to the output area, and sending the goods from the output area to the temporary storage positions of the goods of the automatic pre-sorting and packing modules 4.
The ring-shaped cross belt sorting machine 1 is divided into two sorting areas. Each sorting area comprises a feeding section and a sorting section. The two upper package sections are respectively positioned in the middle of the two straight line sections of the circular cross belt sorting machine 1. The output ends of the two upper wrapping sections are provided with five-surface sweeping equipment 6. The respective pre-sorting and packing-on modules 4 are arranged in sequence at the middle position inside the ring-shaped cross belt sorting machine 1. The automatic pre-sorting and wrapping module 4 can automatically perform primary screening on the goods, divide the goods into two types according to requirements, and respectively convey the goods in opposite directions. The two types of goods in the initial category may be goods in different distribution areas (e.g., the north area of the warehouse and the south area of the warehouse). Two goods output positions for outputting two types of goods on the automatic pre-sorting and wrapping module 4 are respectively butted with the side parts of wrapping sections on the ring-shaped cross belt sorting machine 1.
As shown in fig. 3 and 4, the automatic pre-sorting and packing module 4 comprises a temporary goods storage area 4-1, a weighing and code scanning mechanism 4-2 and two lead-in sections 4-3. Each automatic pre-sorting and packing module 4 corresponds to two packing tables 5; the two upper package platforms 5 are respectively arranged at the opposite ends of the corresponding automatic pre-sorting upper package modules 4 and are respectively butted with two upper package sections of the ring-shaped cross belt sorting machine 1. The temporary goods storage area 4-1 adopts a goods hopper; an inclined slideway is arranged on the goods hopper; the top of the inclined ramp interfaces with the output area of the transfer conveyor 2. The bottom of the inclined slideway is connected with a goods storage area for temporarily storing input goods so as to facilitate the packing operation of workers.
The output area of the transfer conveyor 2 is provided with goods distribution mechanisms corresponding to the number of the inclined slideways. The goods distributing mechanism is arranged on the rack and comprises a distributing plate and a distributing driving mechanism. The inner end of the shifting plate is rotatably connected with the frame and is positioned on one side of the output area of the transfer conveyor 2, which is far away from the inclined slideway. The outer end of the shifting plate is positioned at one side of the inner end of the shifting plate close to the conveying direction of the output area of the transfer conveyor 2.
The shifting plate is driven to turn over by the distributing driving mechanism. The distribution driving mechanism adopts a cylinder. The frame of the cylinder body of the distribution driving mechanism is rotationally connected. The end part of the piston rod is rotationally connected with the side surface of the shifting plate; the turning of the shifting plate is driven by the stretching of the air cylinder. The shifting plate is provided with two working positions; when the shifting plate is at the first working position, the shifting plate is separated from the output area of the transfer conveyor 2; when the shifting plate is turned to the second working position, the shifting plate shifts the goods conveyed on the output area of the transfer conveyor 2 into the corresponding inclined slide way.
The weighing code scanning mechanism 4-2 comprises a weighing conveying mechanism 4-2-1, a mounting bracket 4-2-2, a pre-classification recognition camera 4-2-3 and two buffer sections 4-2-4. The weighing and conveying mechanism 4-2-1 is arranged on the frame, adopts a belt conveyor and weighs through a pressure sensor. The pre-classification recognition camera 4-2-3 is arranged on the rack through the mounting bracket 4-2-2 and is positioned right above the weighing and conveying mechanism 4-2-1, and is used for carrying out image acquisition and scanning operation on goods placed on the weighing and conveying mechanism 4-2-1 and reading information of the goods; according to the information of the goods, the goods are classified, and the goods of different classes are conveyed to the packing platforms 5 in the opposite directions. Two ends of the weighing and conveying mechanism 4-2-1 are respectively butted with the input ends of the two buffer sections 4-2-4. Photoelectric sensors are arranged at two ends above the conveying surface of the weighing and conveying mechanism 4-2-1; and judging the length of the goods according to the time length of the target object detected by the photoelectric sensor and the conveying speed of the weighing and conveying mechanism 4-2-1.
The output ends of two buffer sections 4-2-4 in the same weighing code-scanning mechanism 4-2 are respectively butted with the input ends of two leading-in sections 4-3. The output ends of the two leading-in sections 4-3 are respectively connected with the side parts of the input ends of the two upper packing tables 5; the output end of the upper packing table 5 is butted with the side part of the corresponding upper packing section on the ring-shaped cross belt sorting machine 1. The buffer section 4-2-4, the leading-in section 4-3 and the upper package table 5 are all formed by connecting one belt conveyor or a plurality of belt conveyors in series. An included angle of 60 degrees is formed between the conveying direction of the lead-in section 4-3 and the conveying direction of the corresponding upper ladle table 5; an included angle of 30 degrees is formed between the conveying direction of the upper packing table 5 and the conveying direction of the corresponding upper packing section on the annular sorting machine, so that the goods which are conveyed on the weighing code scanning mechanism 4-2 in the direction vertical to the running direction of the upper packing section of the annular cross belt sorting machine 1 are accurately conveyed to the annular cross belt sorting machine 1.
And a blocking guide plate 7 is arranged on the outer side of the joint of the leading-in section 4-3 and the corresponding upper packing table 5. The blocking guide plate 7 is V-shaped and is divided into a first guide section and a second guide section. The first guide section is flush with the edge of the lead-in section 4-3. The second guide section is aligned with the edge of the input end of the stage 5 remote from the lead-in section 4-3. The blocking guide plate 7 is used for ensuring the stability of the posture of the package in the process of transferring to the upper package table 5 and avoiding the larger deviation of the angle and the position of the package.
Each automatic pre-sorting and packing module 4 comprises two weighing and code scanning mechanisms 4-2. Two weighing code-scanning mechanisms 4-2 are arranged side by side between the two upper packing tables 5. The two mounting brackets 4-2-2 are both mounted between the two weighing and conveying mechanisms 4-2-1, on one hand, the two weighing and conveying mechanisms 4-2-1 are separated, so that a worker can conveniently judge an available placing area, and on the other hand, the situation that the worker is blocked to wrap can be avoided. The goods output by the two weighing code scanning mechanisms 4-2 are all sent into the packaging platform 5 through the leading-in section 4-3.
Both sides of the automatic pre-sorting and packing module 4 are provided with temporary goods storage areas 4-1; two adjacent automatic pre-sorting and packing modules 4 share one temporary goods storage area 4-1; every 4-2 of sweeping yard mechanism of weighing all corresponds and sets up a staff, puts the goods in 4-1 of goods temporary storage area and sweeps yard mechanism 4-2 of weighing.
The conveying direction of the weighing code-sweeping mechanism 4-2 is perpendicular to the running direction of the upper package section of the sorting machine 1 with the annular cross belt, so that the automatic pre-sorting upper package modules 4 are more compact, and the number of upper package workers capable of being arranged in the annular cross belt is increased. In addition, two workers are arranged on the workbench between every two adjacent automatic pre-sorting and packaging modules 4; two workers work back to back without mutual interference. The packages are unloaded from the truck and then automatically conveyed to the temporary goods storage area 4-1 at the side part of the workbench, so that the pre-screening operation of goods entering a warehouse and the operation of manually conveying the goods in the warehouse are omitted, the warehouse space is saved, and the sorting efficiency is improved.
As a preferred technical scheme, the weighing and code scanning mechanism 4-2 comprises a bag control computer, a pre-classification recognition camera 4-2-3, a first conveying belt, a weighing unit and a photoelectric position detection switch, wherein the bag control computer distinguishes that the bag is conveyed to an area A or an area B through a recognition surface sheet, transmits information to an upper computer, controls the belt to rotate forwards and backwards, and binds the weight information of the bag and a bar code.
As a preferred technical scheme, the buffer section 4-2-4 comprises a second conveyer belt and a photoelectric position detection switch, and is mainly used for queuing and temporarily storing packages.
As a preferred technical scheme, the bag loading platform 5 comprises three to seven sections of conveyer belts which are connected in series and are divided into a bag supply input section 4-3, a bag supply acceleration section and a bag supply output section. The speed of the packet supply acceleration section is increased section by section, the packet supply efficiency is gradually increased within 2000-4000 packets/hour, and the more the number of sections of the packet supply acceleration section is, the higher the packet supply efficiency is.
As a preferred technical scheme, the requirement of the automatic supply package on the front-end incoming package is high, the label surface of the incoming package needs to face a specified direction (the label needs to face upwards when the scanner is used for top scanning, and the label cannot face downwards when the scanner is used for five-surface scanning), and the incoming package needs to be made into a single piece, but even if the two-dimensional code of the goods faces upwards during initial packaging, the goods may turn over during transportation, so that the two-dimensional code faces changes; therefore, the bottom surface code scanning device is arranged at the upper package platform 5, and the five-surface scanning device on the annular cross belt sorting machine 1 is matched, so that the condition that the bar codes are not upward due to rolling of packages in the operation process can be effectively identified, and the sorting accuracy is improved. The bottom surface code scanning device is arranged at the gap between the two sections of conveying belts and is arranged upwards.
The working method of the automatic sorting system without manual preliminary sorting comprises the following steps:
and step one, the truck travels to a discharge area at the entrance of the warehouse, and the staff sends the goods to the corresponding feeding conveyor 3.
And step two, the goods pass through the feeding conveyor 3 and the transfer conveyor 2 and enter one temporary goods storage area 4-1.
And step three, sequentially conveying the goods in the goods temporary storage area 4-1 to a weighing code scanning mechanism 4-2 in charge of the staff nearest to the goods temporary storage area 4-1 in a face-up posture.
Fourthly, the weighing conveying mechanism 4-2-1 on the weighing code scanning mechanism 4-2 detects the weight of the goods, and the pre-classification recognition camera 4-2-3 shoots and recognizes the goods; primarily classifying the goods according to the addresses corresponding to the two-dimensional codes on the goods in the images; then, the weighing and conveying mechanism 4-2-1 sends the goods to the packing table 5 corresponding to the primary classification type.
And step five, the upper packing table 5 sends the goods to a sorting trolley at the corresponding upper packing section on the sorting machine 1 with the annular cross belt. When the goods reach the corresponding lower package grid opening in the ring-shaped crossed belt sorting machine 1, the goods are sent into the lower package grid opening, and the automatic sorting of the goods is completed.
In the process, only the process of unloading the freight car and the process of conveying the goods to the weighing and code scanning mechanism 4-2 need to use manpower, the labor cost of primary screening and wrapping at the entrance of a warehouse in the prior art is saved, and the space and equipment cost required by transportation in the warehouse after primary classification are saved.