Sawing machine and method for sawing reinforced aerated concrete plates
The present invention relates to a sawing machine and a method for sawing a workpiece, in particular a building element for a building, preferably a reinforced panel element such as an aerated concrete panel.
Steel-reinforced sheet elements (or sheets or planar elements or slab elements), in particular made of aerated concrete, are also known as structural elements for building buildings and houses, in particular for walls, ceilings or even roofs. Such plate elements usually have the basic shape of a rectangle or cuboid, with the thickness of the wall or ceiling as depth and the width of, for example, 60cm, and the height of, for example, a room as length. The sheet elements are attached to the steel beams of the support structure by welded plates attached to steel stiffeners, which then form, for example, walls or ceilings.
Special geometries occur in certain locations of the house or building, for example, shortened heights such as kneeling, or sloping surfaces such as gable or L-shaped door and window lintels. For such special geometries, it is known to use specially configured circular saws or band saws for processing panel elements having special cut-outs and adapting them to the desired geometry. In addition to simply making shortening cuts, such as height cuts, mention should be made here also of L-shaped cuts with perpendicular cutting surfaces, or chamfer cuts (mitre cuts) with surfaces at an angle of 90 ° to one another, or gable cuts or bevel cuts, or also shifting cuts (shifter cuts) with surfaces inclined in both directions. The various sheet elements adjusted by sawing can be supplied to a specific building after factory assembly, whereby appropriate element assemblies and control software can be used to assemble groups of building elements and calculate and perform an effective control sequence for sawing. The aim here is to achieve a dimensionally accurate machining by sawing and to achieve the most efficient handling of the planar elements in terms of avoiding waste and kerf length.
The object of the invention is now to specify a new sawing machine and a new sawing method. The sawing machine and sawing method are particularly suitable for treating aerated concrete panel elements and preferably also allow high treatment accuracy and high treatment speed.
This object is achieved according to the invention, in particular by the features of claim 1. The dependent claims yield advantageous and further embodiments.
The combinations of features and subject matter according to the invention that can be claimed are not limited to the wording chosen and the backward reference of the claims. Conversely, any feature in a claim category, such as apparatus, may also be claimed in another claim category (e.g., method). Furthermore, any feature in a claim may be claimed in any combination with one or more other features in a claim, also independently of their backward reference. Furthermore, any feature described or disclosed in the specification or drawings may be claimed independently, or separately from and in any combination with one or more other features described or disclosed in the specification or drawings, independently of or apart from the context in which it appears.
In one embodiment, in particular according to patent claim 1, a sawing machine is provided for sawing workpieces, in particular structural elements of buildings, preferably sheet elements, for example made of reinforced aerated concrete, and comprising:
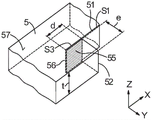
a) a first saw unit having a first saw cutting plane and a second saw unit having a second saw cutting plane,
b) wherein the two saw cutting planes cannot be adjusted (or arranged) parallel (or inclined) to each other,
c) wherein the first saw unit and the second saw unit
c1) Both mounted on a common carrier means,
c2) in each case, the workpieces can be moved into and out of the carrier device independently of one another in the associated feed movement, in each case via the associated feed drive,
d) wherein at least the first saw unit is movable relative to the carrier device for positioning relative to the workpiece in a positioning movement independent of the feed movement by means of a positioning drive,
e) wherein the carrier device together with the two saw units is movable in a working movement relative to the workpiece by means of a drive.
In another embodiment, the first saw unit comprises a first circular saw blade having a first axis of rotation and a first rotary drive for rotating the first circular saw blade about the first axis of rotation, wherein a first saw cutting plane is defined by the first circular saw blade and is oriented perpendicular to the first axis of rotation.
In another embodiment, the second saw unit comprises a second circular saw blade having a second axis of rotation and a second rotary drive for rotating the second circular saw blade about the second axis of rotation, wherein a second saw cutting plane is defined by the second circular saw blade and is oriented perpendicular to the second axis of rotation.
In a preferred embodiment, the first rotary drive is arranged vertically above and/or orthogonal to the first axis of rotation of the first circular saw blade and is preferably coupled to the hub of the first circular saw blade by a bevel gear.
In one embodiment, the second rotary drive is arranged horizontally and/or axially with respect to the axis of rotation of the second circular saw blade, and is preferably coupled directly axially to the hub of the second circular saw blade, which is preferably arranged to be concave on the side facing away from the rotary drive.
The sawing machine preferably has one or more of the following features:
a) the second saw unit can also be moved relative to the carrier device by means of a feed drive for positioning relative to the workpiece with a positioning movement independent of the feed movement,
b) the saw cutting plane is vertically adjustable or adjusted (or: an arrangement),
c) the saw cutting planes are adjustable or are adjusted orthogonally to each other,
d) the feed movement of at least one and preferably both saw units is or are linearly and/or vertically adjustable,
e) the positioning movement of the saw unit is adjustable or adjusted linearly and/or horizontally,
f) the working movement of the carrier device is linearly and/or horizontally adjustable or regulated linearly and/or horizontally,
g) the working movement of the carrier device and the positioning movement of the saw unit are adjustable or are adjusted orthogonally to each other.
Preferably, the carrier device comprises a boom extending preferably along the central axis, which boom is arranged or can be arranged above and/or suspended over the workpiece, wherein the saw unit is mounted on the boom. The central axis of the boom is preferably oriented horizontally. The positioning movement is preferably oriented parallel to the central axis of the cantilever. The feed motion is preferably oriented orthogonal to the central axis of the boom.
In a particular embodiment, the cantilever is mounted to rotate (or pivot), preferably horizontally, about a swivel axis, preferably a vertical swivel axis, in particular in order to perform a tilting or bevelling cut.
In a further embodiment, a swiveling drive arranged on the carrier device is assigned to one or both saw units for swiveling the respective saw cutting plane relative to the carrier device (in particular the boom).
Preferably, for the feed movement, each saw unit is connected via a carrier or holder to a carriage which is movably guided on or in an associated guide rail on the feed carrier (in particular a vertical carrier) and is driven or drivable by a displacement drive. The feed carriers of the two saw units are preferably arranged on opposite sides of the boom. For the positioning movement, the feed carrier of the first saw unit is preferably displaceably guided in a positioning rail on the boom and is driven or drivable by a feed drive, which positioning rail preferably extends parallel to the central axis of the boom.
In an advantageous embodiment, the sawing machine comprises a support device for supporting the workpiece, the carrier device and the support device being movable relative to each other in a working movement, the at least one drive preferably being associated with the carrier device or the support device, and the support device preferably having a guide rail for guiding the carrier device during the working movement.
In a particularly advantageous embodiment, the support device has a plurality of support elements which can be folded up and down by means of a folding drive in order to clear the cut-out portion of the workpiece by folding down a selected support element (on which the cut-out portion rests at least in the upward folded state of the selected support element) and laying down the corresponding cut-out portion. The foldable support elements are preferably arranged in rows one after the other and serve to support edge regions of the workpiece. Between at least a part of the foldable support element in the folded-up position and the further support element, a machining slot is preferably formed, which is used for trapping the circular saw blade during the sawing step.
Generally, the sawing machine also comprises at least one control device which is operatively connected or in communication with all the drives and automatically implements the saw cuts to be produced for processing the workpiece by means of implemented software or NC control (numerical control) and predetermined geometric setpoint data.
A method for sawing workpieces, in particular structural elements, preferably sheet elements, for buildings, for example made of reinforced aerated concrete, using a sawing machine according to an embodiment of the invention, comprises the following method steps in one embodiment:
(i) a first saw cut completely penetrating the thickness of the workpiece is produced by a second circular saw blade which is set into working rotation by an associated second rotary drive and is already in a feed position or is moved with a feed movement, preferably a vertical feed movement, into a feed position in which the second circular saw blade reaches the workpiece with its region facing the workpiece, preferably the lower region, preferably from above, over the entire thickness of the workpiece, through the entire workpiece, and is moved, starting from the edge of the workpiece, through the workpiece by means of a working movement of a carrier device,
(ii) a second saw cut is produced which penetrates completely through the thickness of the workpiece by means of a first circular saw blade which is set into working rotation by means of an associated first rotary drive and has been moved by means of a positioning movement into a position at the edge of the workpiece, and the second saw cut is produced only by means of a feed movement.
Furthermore, according to the invention, a method for sawing workpieces, in particular for structural elements of buildings, preferably plate elements, for example made of reinforced aerated concrete, is proposed, wherein an inner corner region is produced in the workpiece, having the following method steps:
(i) in a first sawing step, a first saw cut is produced in the workpiece by means of the circular saw blade, wherein the first saw cut extends from an edge of the workpiece into an end region still within the workpiece and extends over the entire depth of the workpiece, and wherein a curved cut inner edge remains in the end region, which curved cut inner edge depends on the outer contour of the circular saw blade and the feed or outward movement of the circular saw blade,
(ii) in a second sawing step, a second saw cut is produced in the workpiece, which second saw cut starts from an edge of the workpiece and extends to the first saw cut in a region spaced apart from the end of the first saw cut,
(iii) the parts of the workpiece cut out by the first saw cut and the second saw cut are removed in a first cleaning step,
(iv) in a third sawing step, a third saw cut is produced, as a repeat cut (re-cut) or relief cut of the first saw cut, through the entire depth of the workpiece in the end region of the first saw cut, with the same circular saw blade as in the first sawing step, whereby the cut inner edges are completely removed and an inner edge, preferably a straight inner edge, of the third saw cut is formed at the end region of the first saw cut supplemented or reworked by the third saw cut.
(v) In a fourth sawing step, a fourth saw cut is made in the workpiece, the fourth saw cut extending from an edge of the workpiece to an inner edge at the third saw cut,
(vi) in a second cleaning step, the part of the workpiece that is divided by the first saw cut released from the fourth saw cut and from the cut inner edges in the end regions of the first saw cut, or divided by the fourth saw cut and the first saw cut released from the cut inner edges in the end regions of the first saw cut, or divided by the fourth saw cut and the third saw cut, is removed, thereby forming an inner corner region formed by the first saw surface released from the first saw cut and the third saw surface released from the third saw cut and by the inner edges at the third saw cut.
This method for creating an interior corner region is preferably implemented using a sawing machine according to an embodiment of the invention. Preferably, the first saw cut in the first sawing step and the third saw cut in the third sawing step are generated by a second circular saw blade, preferably by a working movement of the carrier device. Furthermore, the second saw cut in the second sawing step and the fourth saw cut in the fourth sawing step are preferably generated by the first circular saw blade, preferably only by a feed movement and not by a movement of the carrier device.
The part of the workpiece that at least partially rests on the at least one support element and is divided by the first saw cut and the second saw cut is advantageously removed in a first removal step by folding the at least one support element downwards. Preferably in the second cleaning step, the part of the workpiece which at least partially rests on the at least one further support element and which is divided by the fourth saw cut and the first saw cut released by the third saw cut from the cut inner edge in the end region of the first saw cut or divided by the fourth saw cut and the third saw cut is removed by folding down the at least one further support element.
The invention is further explained below by means of examples of embodiments. Reference is also made to the accompanying drawings, wherein
Figure 1 is a perspective view of a sawing machine with a sheet element,
figure 2 is a side view of the sawing machine of figure 1,
figure 3 is a top view of the sawing machine according to figures 1 and 2,
fig. 4 shows, in perspective view, after sawing of the longitudinal sections, a section of the sheet element,
fig. 5 shows in perspective a part of a sawing machine during sawing in a first transverse cut;
fig. 6 shows, in perspective view, a portion of the sheet element after sawing of the first transverse portion;
FIG. 7 shows in perspective a portion of a sawing machine during subsequent sawing of the longitudinal relief cut;
fig. 8 shows, in perspective view, a portion of a sheet element,
figure 9 shows in perspective a part of the sawing machine during sawing of the second transverse cut,
figure 10 shows in perspective a portion of the sheet element after sawing of the second transverse portion;
figure 11 shows in perspective a part of the sheet element with a final L-shaped cut after sawing of the second transverse cut and evacuation of the scrap, an
Fig. 12 is a perspective view of the sawing machine with the final sawn sheet element having L-shaped cuts and the sawing machine in a parking position.
In each case shown schematically. In fig. 1 to 12, corresponding parts and dimensions are marked with the same reference signs.
In fig. 1-12, a cartesian x-y-z coordinate system is input for spatial reference of the component and its motion. The x-axis and the y-axis run through the horizontal plane, while the z-axis corresponds to the vertical direction.
The sawing machine according to fig. 1 to 5 is provided for sawing (or: sawing process, producing saw cuts, cutting to size) a workpiece, in particular a sheet element 5 (or: sheet, planar element, slab). The sheet element 5 is provided in particular as a building element for constructing a building or a house, in particular as a wall element or a ceiling element, and is preferably, but not limited to, reinforced (or: strengthened) in general, in particular steel reinforced (or: steel reinforced) aerated concrete element.
The sheet element 5 is placed on a table or frame-like support means 3. The free upper surface or top side of the laid sheet element 5 is marked 57. With regard to the sheet element 5, in particular the support means 3 comprise a continuous support element 36, and support elements 31, 32, 33 and 34, as well as wear pads 30, the support elements 31, 32, 33 and 34 can be folded up and down by means of a folding drive, not shown in more detail, and are preferably aligned one after the other in the x-direction.
In order to position or readjust the position of the sheet element 5 in the x-y plane on the support device 3, a slide or positioning unit with adjustable stops is provided, wherein a positioning unit 70 for positioning or readjustment in the y direction and a positioning stop 37 of a further positioning unit, not shown, on the end face 58 of the sheet element 5 for positioning or readjustment in the x direction are shown. Typically, at least two positioning stops and units in opposite x-direction and-x-direction and at least two, preferably at least four positioning stops and units in opposite y-direction and-y-direction are provided on the side 59 of the sheet element 5.
In particular, the sheet element 5 may be an aerated concrete element, typically reinforced with steel reinforcements. In principle, however, the sawing machine can also be used for sawing other workpieces with similar requirements. The sheet element 5 has a length, here measured in the x-direction, typically of 2m to 8m, for example 6m, a width in the y-direction typically of 0.3m to 1m, for example 0.60m, and a thickness, denoted t, corresponding to the desired wall thickness, for example of about 0.1m to 0.6 m. The end face forming the edge of the sheet element 5 is indicated with 58, while the side face is indicated with 59 and the top face is indicated with 57.
Sawing machines are used for making the various saw cuts that may occur in house construction, preferably straight transverse cuts for height cutting or L-shaped cutting, but also for miter cuts, such as gable cuts or bevel cuts, if necessary, and also for displacement cuts, if necessary. From a sheet or sheet element 5 of standard dimensions having a predetermined, for example substantially rectangular sheet shape, an assembled fitting element is produced by means of a sawing process (which has steps and/or bevelings and/or bevels and/or shifting cuts produced by the sawing process). For this purpose, the sawing machine should receive specifications for the number and shape of the individual assembly elements, in particular by means of componentization software or manufacturing software, and calculate and execute the movement control of the saw blades 10 and 20 accordingly. The dimensional accuracy should be as high as possible, i.e. the movement tolerances of the saw unit should be as small as possible.
The sawing machine comprises (at least) two circular saw blades 10 and 20. Each circular saw blade 10 and 20 defines a saw cutting plane and is arranged in this saw cutting plane so as to be rotatable about a rotational axis D1 and D2, respectively, and is driven in an associated rotational or swiveling movement or direction, respectively, by an associated rotary drive 11 and 21, respectively, via an output shaft (fastened to an associated hub (with a fastening flange) 19 and 29, respectively, in the center of the circular saw blades 10 and 20, respectively).
The circular saw blades 10 and 20 have a cutting or dividing outer contour as saw structure with a basic shape which substantially follows a circle or extends around the rotational axis D1 or D2 with a constant radius R1 or R2. The peripheral speed corresponding to R12 pi f1 or R22 pi f2 at speeds f1 and f2 is typically between 30 and 80 m/s.
The maximum free radius (free radius) of the annular region available for the sawing operation on the working faces of the circular saw blades 10 and 20 is denoted Δ R1 and Δ R2, respectively, and in particular corresponds to the distance from the central hub 19 to the outer contour in the case of the first circular saw blade 10 or to the distance by which the rotary drive 21 projects further than the hub 29 in the case of the second circular saw blade 20. The two free radii Δ R1 and Δ R2 are preferably selected to be greater than the thickness t of the sheet element 5, so that a continuous saw cut can be made through the sheet element 5 and sub-regions of the sheet element 5 can be completely cut off.
Preferably, the hub 29 on the second circular saw blade 20 is recessed or countersunk or flush on the machining side facing away from the rotary drive 21, i.e. it does not protrude outwards, so that no obstacle to the sawing operation is formed at this machining side.
The circular saw blades 10 and 20 are designed in particular as cutting disks with hard material particles, for example corundum or diamond, incorporated in a metal matrix, preferably in the form of segments, but it is also possible to have a saw tooth structure on the outer contour.
The radius of the circular saw blades 10 and 20, i.e. the distance of their outer contour from the respective axis of rotation D1 or D2, is chosen to be larger than the thickness of the sheet element 5 to be sawn through, so that machining is possible from only one side of the sheet element 5.
In the position shown in fig. 1-5, circular saw blades 10 and 20 and their saw cutting planes are aligned vertically (i.e., including a direction parallel to the z-axis) such that rotational axes D1 and D2 are horizontally aligned or parallel to the x-y plane. Furthermore, the circular saw blades 10 and 20 and their rotational axes D1 and D2 are arranged orthogonal, i.e. at right angles, to each other. Thus, it is possible to initially make a longitudinal cut in the x-z plane and a transverse cut in the y-z plane.
Preferably, the rotary drive 11 is arranged vertically, with its output shaft perpendicular to the axis of rotation D1 and oriented in the z direction, which is coupled to the drive shaft of the circular saw blade 10 via a gear, in particular a bevel gear. Together with the short carrier 13, a compact and space-saving first saw unit 14 formed by the circular saw blade 10 and the rotary drive 11 is thus formed. The rotary drive 21 is preferably horizontal, the output shaft of which is oriented axially with respect to the axis of rotation D2 and which directly forms the drive shaft of the circular saw blade 20 in the form of a direct drive. The carrier 23 is here designed as an approximately longer arm or cantilever.
The first saw unit 14 comprising the first circular saw blade 10 and the rotary drive 11 is linearly displaceable in a vertical displacement movement or in a displacement direction V1 along the z-direction. For this purpose, the first saw unit 14 is connected via a carrier 13 to a linear drive 12, which linear drive 12 is displaceably driven by means of a displacement drive, not described in greater detail, in a displacement movement or direction V1 on or in an associated guide rail 41 on a vertical carrier 15.
Thus, the second saw unit 24 comprising the second circular saw blade 20 and the rotary drive 21 can be displaced linearly in a vertical displacement movement or in a displacement direction V2 along the z-direction independently of the first saw unit 14. For this purpose, the second saw unit 24 is connected via a carrier 23 to a linear drive 22, which linear drive 22 is displaceably driven in a displacement movement or direction V2 on or in an associated guide rail 42 on the vertical carrier 25 by means of a displacement drive or feed drive, which is not explained in more detail.
Two vertical displacement movements V1 and V2 are provided for feeding the circular saw blades 10 and 20 downwards (negative z-direction) into the sheet element 5 and into the sheet element 5, and for moving the circular saw blades 10 and 20 upwards (positive z-direction) out of the sheet element 5 and away from the sheet element 5. The linear displacement unit with the guide rails 41 and 42 and the displacement drive or feed drive can be formed very accurately and with low tolerances.
Two vertical carriers 15 and 25 for the first saw unit 14 and for the second saw unit 24 are mounted or formed on opposite sides of the elongated boom 40. The cantilever arms 40 are suspended or mounted above the sheet element 5 across the width of the sheet element 5 in the y-direction and are part of the carrier device 4.
As a further freedom of movement, the carrier device 4 is guided in a linear guide 74 on the support device 3 for a linear longitudinal movement L in the x-direction and can be moved by a linear drive, which is not shown in more detail. As a result, the second saw unit 24 with the second circular saw blade 20 (and thus also the first saw unit 14 with the first circular saw blade 10, the first saw unit 14 being coupled with the second saw unit 24 by means of the cantilever arm 40) can be moved in the longitudinal direction of the sheet element 5 with a longitudinal movement L and can produce longitudinal saw cuts in the x-direction.
In the support device 3, in particular between the foldable support elements 31 to 34 on the one hand and the continuous support element 36 on the other hand, at least one machining slot (or: insertion slot) 38 is arranged and formed, through which a circular saw blade can be inserted downwards during the sawing operation. In the exemplary embodiment shown, the machining slot 38 is arranged in a fixed y-position or parallel to the longitudinal direction or movement L and is provided for the second circular saw blade 20, which second circular saw blade 20 sinks into the machining slot 38 when the longitudinal saw cut (in the y-direction) is produced, in order to be able to saw through the entire thickness t of the sheet element 5.
In order to introduce a further degree of freedom for adjusting the saw cutting plane, the cantilever 40 may be designed as a swivel cantilever, which is connected to the swivel rim 43, for example via a rib 47. The swivel flange 43 and the swivel boom 40 attached thereto can be swiveled by the swivel drive 44 about a swivel axis SA in the vertical or z direction in a swivel motion SB and thus parallel to the x-y plane in a swivel motion SB. The (pivoting) boom 40, the pivoting flange 43 and the pivoting drive 44 now together form a pivoting carrier device 4 for pivoting the two circular saw blades 10 and 20 and their saw cutting planes by a certain pivoting angle in a horizontal pivoting plane parallel to the x-y plane in accordance with a pivoting movement SB.
The bearing of the carrier device 4 can be designed very precisely and with low tolerances, since the swivel movement SB is only one-dimensional or has only one degree of freedom.
Depending on the pivoting position of the pivoting boom 40, the first circular saw blade 10 can saw the sheet metal element 5 on a side remote from the pivoting axis SA which is different from the vertical cut in the y-direction, i.e. can cut at an internal or beveling angle α of 90 ° as shown in fig. 1, or can also cut at an internal or beveling angle α which deviates from 90 ° after a corresponding pivoting movement SB of the carrier device 4 about the pivoting axis SA through a certain pivoting angle.
In order to allow adaptation to different widths of the sheet element 5 or to different positions of the saw cut in the y direction, the vertical carrier 15 (on which the first saw unit 14 is guided) together with its first circular saw blade 10 can be moved by a transverse drive, not shown in greater detail, in a transverse movement T1 in a transverse guide rail 45 parallel to the central axis 46 of the cantilever arm 40.
The second circular saw blade 20 now makes a longitudinal cut or longitudinal saw cut in the sheet element 5 in the x-direction.
The longitudinal cut through the sheet element 5 in the x direction is preferably provided at a predetermined y position, at which the second circular saw blade 20 is positioned and the cantilever arm 40 extends vertically or in the y direction, and at which a machining slot 38 extending through in the x direction is located between the raised support elements 31, 32, 33 and 34 on the one hand and the support element 36 on the other hand, into which machining slot 38 the second circular saw blade 20 can be inserted in the z direction.
In order to also be able to produce saw cuts, in particular longitudinal saw cuts, with different positions in the y direction of the second circular saw blade 20 or in different transverse positions, in a not shown embodiment, it is in principle also possible to provide a transverse guide and a transverse drive on the side of the cantilever arm 40 to move the vertical carrier 25 of the second circular saw blade 20 along the cantilever arm 40 or its longitudinal axis 46, in particular along the transverse movement T2 in the y direction.
Furthermore, it is also conceivable that the cantilever 40 can be displaced in the direction of its longitudinal axis 46 along a transverse movement by means of a displacement drive or linear drive, not described in more detail, in particular relative to the swivel rim 43.
The drive and the degrees of freedom achieved in this way for the two circular saw blades 10 and 20 make it possible to carry out a large number of different machining cuts for the sheet element 5. The freedom for moving the two circular saw blades 10 and 20 in the intended working space is achieved by simple linear drives and linear guides, which can be performed with little play on the one hand and by rotary drives and rotary bearings on the other hand, which increases the precision and speed (response behavior) of the machining, for example, in the case of two industrial robots, a larger design leads to greater stability but also to higher inertia, resulting in longer cycle times, compared to the implementation of two industrial robots.
More generally, according to the invention, a sawing machine is proposed having two circular saw blades which are not arranged parallel to each other or cannot be adjusted parallel to each other, wherein the two circular saw blades are supported or mounted on a common carrier device, and wherein
The carrier device with the two circular saw blades can be moved in a first working movement relative to the workpiece or the support device by means of a drive, preferably the support device is stationary and the carrier device is moved by means of an associated drive, or, in the alternative, the support device is moved by means of an associated drive (for example in the form of a conveyor belt or the like) and the carrier device is stationary or stationary.
At least one circular saw blade is movable in a second working movement relative to the carrier device,
in each case two circular saw blades can each be moved into or out of the workpiece in a feed movement relative to the carrier device by means of an associated feed drive,
optionally, the carrier device can be swivelled together with the two circular saw blades, and
optionally, at least one circular saw blade is rotatable relative to the carrier device.
The two circular saw blades or their rotational axes are preferably arranged or adjustable perpendicular to each other.
The first working movement of the carrier device can in principle follow any trajectory possible with a circular saw blade, but an in-plane working movement, and preferably a linear movement, i.e. a linear movement or a movement along a straight line, is preferred. One of the circular saw blades produces a saw cut substantially during the first working movement and is adjusted or arranged relative to the carrier device for this purpose such that the axis of rotation of the circular saw blade is oriented perpendicular to the trajectory, preferably perpendicular to the line of the first working movement of the carrier device. The first working movement is preferably used to produce a lengthwise or longitudinal cut.
The substantially arbitrary trajectory of the second working movement does not follow the same trajectory as the first working movement, but in particular also lies in a plane, and preferably also follows, as a linear movement, a straight line which is preferably oriented at an angle to the plane or straight line of the first working movement, which angle is preferably 90 °, i.e. orthogonal to the plane or straight line of the first working movement. The second working movement serves primarily for positioning the respective circular saw blade relative to the workpiece, but can also be used for cutting notches in the workpiece during the second working movement of the circular saw blade.
In particular, the feed movement of each circular saw blade is a linear movement along a straight line which is preferably oriented perpendicular to the trajectory or plane or line of the first working movement and/or perpendicular to the trajectory or plane or line of the second working movement. The feed movement is preferably also used to produce saw cuts in the workpiece during the feed movement. For example, transverse cuts can be made in order to make internal corner regions, in particular L-shaped cuts, together with longitudinal cuts.
An optional swiveling movement of the carrier device together with the two circular saw blades is used, for example, to produce a bevel cut.
The optional rotatability or setting of different angles of rotation of the circular saw blade is preferably used to produce oblique cuts, such as bevel cuts or shift cuts.
The sawing system also comprises control means, not shown, which are connected or communicate with all the mentioned drives by means of wired or also wireless control techniques and which automatically execute the saw cuts to be produced in accordance with the implemented software or NC control and predetermined geometric data (e.g. position, orientation and angle) to produce a specific pattern of workpieces, in particular sheet material elements.
With sawing machines, a large number of sawing operations and sequences of sawing operations on the same workpiece can be performed in a very versatile manner.
With reference to fig. 1 to 12, a particularly advantageous machining process that can be carried out with a sawing system, which is provided for producing an inner corner region on or in a sheet element 5 (as an example of a generic workpiece), will now be presented. In the inner corner region, the two flat cut-out surfaces meet at the inner edge. In particular, the inner corner region is intended to be a rectangular or angular inner corner region or L-shaped portion formed by a longitudinal cut surface 51 and a transverse cut surface 54 that intersect at an inner edge 56. The movement sequences described here are preferably stored in the control device in software and are realized by controlling the respective responsible drive in each operating step.
First, in the positioning step, the still intact cuboid plate element (or: flat element, sheet, slab) 5 is placed on the support device 3 and its position is adjusted or centered by the positioning units 37 and 70. The sheet element 5 is positioned such that the y-position of the longitudinal cut S1 still to be produced in the sheet element 5 is located just above the machining slot 38 of the support means 3.
Now, as the circular saw blades 10 and 20 are raised, the carrier device 4 (on which the two saw units 14 and 24 are positioned) is moved in a longitudinal movement L to an initial position at the ends of the sheet element 5, so that they assume a position substantially as shown in fig. 12. The second circular saw blade 20 is now located at the end face 58 of the sheet element 5 with respect to the x position and still above the sheet element 5. The second circular saw blade 20 has been advanced laterally to the correct y position above the machining slot 38.
In the initial position, the foldable support elements 31 to 34 are initially all folded upwards and together with the support element 36 support the positioned sheet element 5 from below (not shown).
Now, in the first sawing step for producing the longitudinal cut S1, the second circular saw blade 20 (already in working rotation by the rotary drive 21) is passed through the vertical carrier 25 for the second saw unit 24 in the-z direction with a vertical displacement movement V2 down through the sheet element 5 down to its full depth t and the lower edge region is sunk into the machining slot 38. The second circular saw blade 20 descends in the-z direction to a depth less than the free radius ar 2 so that the rotary drive 21 remains above the sheet element 5. At the same time, the descending second circular saw blade 20 is guided through the sheet element 5 starting from the end face 58 of the sheet element 5 by a longitudinal movement L of the carrier device 4 in the-x direction. This produces a continuous longitudinal saw cut S1 in the sheet element 5 in the-x direction along the machining slot 38, the width of the saw cut corresponding to the width (or thickness) of the second circular saw blade 20.
At the end of the longitudinal movement L of the second circular saw blade 20 in the x direction by the predetermined length, the second circular saw blade 20 is again pulled or guided upwards out of the sheet element 5 in the z direction, i.e. the longitudinal cut S1 ends, because the second circular saw blade 20 stops its longitudinal movement L and now moves upwards again with a displacement movement V2 and extends out of the sheet element 5. The first sawing step is thus completed.
In fig. 4, a part of the sheet element 5 is shown, which has a longitudinal cut S1 after the first sawing step. The longitudinal cut S1 ends with an end region in the sheet element 5. Due to the geometry of the circular saw blade 20, the remaining area or cutting edge 53 that is not sawn remains in the end area of the longitudinal saw cut S1, having the thickness of the second circular saw blade 20 or the width of the first saw cut S1. The shape of this cutting edge 53 is substantially arc-shaped or crescent-shaped and depends not only on the radius R2 of the second circular saw blade 20 but also on its outward movement in the z-direction at the end of the first sawing step. However, since the maximum penetration depth of the free radius Δ R2 of the second circular saw blade 20 in the first sawing step is limited, the cutting edge 53 is unavoidable.
The sub-region cut out by the first saw cut, longitudinal cut S1 on one longitudinal side and subsequently divided in the subsequent second sawing step, which sub-region corresponds to the distance of the longitudinal saw cut S1 from the side 59 of the sheet element 5 and of course also to the thickness t of the sheet element 5, is denoted a1 and has a width e in the y-direction. On the side opposite to the sub-area a1 of the sheet element 5 where the sub-area a1 is not retained, the longitudinal kerf surface 51 has now been formed as a first kerf surface which, however, ends unevenly at the cutting edge 53 and has not yet ended with a straight edge as desired.
In order to completely sever this sub-region a1 and simultaneously remove the cutting edge 53, three further sawing steps are now provided according to the invention.
In the second sawing step, a first transverse saw cut S2 is first produced as a second saw cut at a distance d, measured in the x-direction or the longitudinal movement direction L or the direction of the longitudinal saw cut S1, starting from the end region of the longitudinal saw cut S1 or also from the farthest point of the cutting edge 53. The first transverse saw cut S2 extends from the side 59 of the panel element 5 to the longitudinal cut S1 or also to the longitudinal cut surface 51.
To create the first cross cut S2, a first circular saw blade 10 is preferably used, as shown in fig. 5. For this purpose, after the first sawing step, the carrier device 4 and the two saw units 14 and 24 are first moved back a small distance in the x-direction again with a longitudinal movement L until the first circular saw blade 10 is located at a distance D from the end region of the longitudinal cut S1 or the farthest point of the cutting edge 53, the rotation axis D1 being oriented in the x-direction. The first circular saw blade 10 is moved or has been moved in advance by a transverse movement T1 in the y direction in such a way that the outer contour in the y direction ends in a longitudinal cut S1, preferably in a longitudinal cut surface 51, so that the first axis of rotation D1 is arranged at a distance of the radius R1 of the first circular saw blade 10 from the plane containing the longitudinal cut surface 51.
The first transverse cut S2, which is the second saw cut, is now preferably formed by a completely vertical working movement of the first circular saw blade 10, which first circular saw blade 10 is moved downwards through the sheet element 5 in a vertical displacement movement V1. For this purpose, the free radius Δ R1 of the first circular saw blade 10 is greater than the width e of the subregion a1, which corresponds to the distance of the first saw cut or longitudinal cut S1 from the side face 59. The arrangement of the rotary drive 11 vertically above the axis of rotation D1 of the first circular saw blade 10 also facilitates this vertical movement of the first circular saw blade 10.
After the first transverse cut T1, sub-region a1 is now exposed and cut away all around, and may be removed or cleared. This is shown in fig. 6. After the cross-cuts S2 are cut, the first cross-cut surface 52 is now opposite the subregion a1 divided by the cross-cut S2.
Now, in a first cleaning step, cleaning is carried out in an advantageous manner by means of the foldable support element. As the foldable support elements 32 to 34 are folded down by the folding actuators, the support of the now fully divided part a1 of the sheet element 5 is removed and this divided part a1 falls down by gravity at this time and can be removed immediately or later.
This removal of sub-area a1 creates room for the next third sawing step. The third sawing step occurs after the first removal step and serves to completely remove the cutting edge 53 left in the end region of the longitudinal cut S1 in the first sawing step. In the third sawing step, the longitudinal cut S1 may remain unchanged in its (maximum) length or may also be slightly elongated.
In a third sawing step, the second circular saw blade 20 is now preferably used again, as shown in fig. 7. For this purpose, after the first sawing step, the carrier device 4 is first moved slightly in the-x direction again together with the two saw units 14 and 24 in a longitudinal movement L until the second circular saw blade 20 is arranged above the cutting edge 53. In this case, the x-position of the second circular saw blade 20 is preferably set in the x-direction such that the outer contour of the second circular saw blade 20 ends, as projected downwards in the z-direction, at the end point of the longitudinal cut S1, i.e. at a distance d from the first transverse cut surface 52, or may also slightly exceed this distance. For the positioning movement, the control device controls the longitudinal drive accordingly.
In the third sawing step, a third saw cut is produced as a repeated cut S3 of the longitudinal cut S1 by the second circular saw blade 20 moving vertically downwards in the first saw cut or longitudinal cut S1 only with a vertical displacement movement V2 and cutting off the cutting edge 53 over the entire thickness t of the sheet element 5. This creates a clean vertical end surface or edge on the longitudinal cut S1, eventually forming an inner edge 56 on the longitudinal cut surface 51 of the double cut. This vertical downward movement of the second circular saw blade 20 can now be performed further than in the first sawing step, since now a free working space has been created by the treatment of sub-area a1 and the folding down of the support element, in particular the support element 32. The drive 21 can now move freely downwards in this release working space with a displacement movement V2 and can no longer abut against the sheet element 5 or the support element 32. On the machining side of the second circular saw blade 20 facing the longitudinal cut surface 51, a recessed hub 29 is arranged, which hub 29 can also be moved past the longitudinal cut surface 51 or surface.
The result of the third sawing step is shown in fig. 8. In fig. 8, the volume covered by the double cut S3 and the material of the now cleaned sheet element 5 cut or cut away is indicated by shading for illustration. The cutting edge 53 from the first sawing step is now completely removed.
It can also be seen that the free radius ar 2 of the second circular saw blade 20 must not only be greater than the thickness t of the sheet element 5, but also greater than the distance d to allow the formation of a third saw cut or compound cut S3.
A fourth sawing step and a subsequent second removal step are now performed to complete the inner corner regions.
In a fourth sawing step, shown in fig. 9, the first circular saw blade 10 is again inserted and positioned in the same way as in the second sawing step, but now offset in the-x direction by a distance d from the first transverse kerf surface 52. For this purpose, after the third sawing step, the carrier device 4 is first moved back a little in the x direction again together with the two saw units 14 and 24 in a longitudinal movement L until the first circular saw blade 10 is spaced apart from the first transverse cut surface 52 by a distance d. The first circular saw blade 10 is positioned or kept positioned again by the transverse movement T1 in the y direction so that the outer contour in the y direction of the longitudinal cut S1 and its multiple cut S3 ends exactly at the end edge created in the third sawing step, preferably at the inner edge 56 of the longitudinal cut surface 51, because the first rotational axis D1 is arranged at a distance of the radius R1 of the first circular saw blade 10 from the plane containing the longitudinal cut surface 51.
As with the second sawing step, the fourth saw cut or second transverse cut S4 in the fourth sawing step is also produced by the vertical displacement movement V1 of the first circular saw blade 10 only.
The result of the fourth sawing step is illustrated in fig. 10. A cut-out portion a2 is formed, the cut-out portion a2 being cut out all around and bounded by the third saw cut S3 and the fourth saw cut S4 as well as the side 59 and the first transverse cut surface 52. The second transverse cut surface 54 is now formed on the remaining sheet element 5 at the fourth saw cut S4, the fourth saw cut S4 divides the second transverse cut surface 54 from the portion a2, and the second transverse cut surface 54 is opposite the portion a 2.
In a second cleaning step, the divided part a2 is processed at this time. Still due to the folding down of the support element 32, the clearing occurs by itself, as the divided portion a2 falls by itself due to gravity.
The end result of the removal of portion a2 is shown in fig. 11. In the sheet element 5 a final inner corner area is formed having two sides, a longitudinal cut surface 51 and a second transverse cut surface 54, which meet at a right angle to a regular inner edge 56.
Now, as shown in fig. 12, the entire unit with the carrier device 4 and the two saw units 14 and 24 is moved back to the front end at the end face 59 of the sheet element 5, and the final sheet element 5 with the inner corner regions can be removed from the support device 3 or can also be further processed. The length of the L-shaped cut or longitudinal cut surface 51 in the L direction is denoted by f.
In the embodiment shown, the carrier device 4 and its cantilever 40 are kept in a non-tilted state during the four sawing steps, i.e. the central axis 46 of the cantilever 40 remains oriented in the y-direction, and the internal angle or chamfer alpha is set to 90 deg..
However, by turning the carrier device 4 beforehand, the first circular saw blade 10 can also produce oblique transverse cuts 52, for example bevel cuts.
In an embodiment not shown, one or each of the circular saw blades 10 and 20 can also swivel about their rotational axes D1 and D2, preferably downwards, but possibly also upwards, with respect to the z-axis or horizontal x-y plane. In particular, in this way it is also possible to produce shifted cuts or cuts with an inclined cutting surface (which is inclined by a certain swivel angle with respect to the z-axis). The swivel angle can be fixed in a simple manner, but is preferably variably adjustable over a range of swivel angles by a motorized swivel drive (not shown) of the system controller.
The manufacture of the inner corner region according to the invention is preferably carried out by means of the sawing device according to the invention.
However, the described processing steps for manufacturing the inner corner regions can also be carried out with other sawing devices. For example, each of the circular saw blades 10 and 20 may be arranged on and moved under the control of an associated industrial robot. Furthermore, it is also possible to perform all sawing steps using only a single circular saw blade, which is attached to and guided by the industrial robot in a controlled manner. Further, a band saw or a chain saw may be used instead of the first circular saw blade.
List of reference marks
3 support device
4 carrier device
5 sheet element
10 circular saw blade
11 Rotary drive
12 Linear driver
13 vector
14 first saw unit
15 vertical carrier
19 hub
20 circular saw blade
21 rotary driver
22 linear driver
23 vector
24 second saw unit
25 vertical carrier
29 hub
30 wear-resistant pad
31 to 34 foldable support element
35 machining gap
36 support element
37 positioning stop
38 machining the slot
40 cantilever
41, 42 guide rail
43 swivel rim
44 slewing drive
45 transverse guide rail
46 central axis
47 Linear guide
51 longitudinal incision surface
52 transverse incision surface
53 cutting edge
54 transverse incision surface
55 Release incision
56 inner edge
57 top surface
58 end face
Side surface 59
70 positioning unit
74 linear guide rail
Thickness D
E width
Length of F
Cartesian coordinates of x, y, z
Sub-partitions of A1, A2 partitioning
D1, D2 rotation axis
L longitudinal movement
S1, S2, S3 saw cut
Axis of revolution of SA
SB rotary motion
R1, R2 radius
Δ R1, Δ R2 free radius
T1, T2 lateral movement
V1, V2 displacement motion and feed motion
The internal angle α.