CN114904779A - Automatic gasket detection machine - Google Patents
Automatic gasket detection machine Download PDFInfo
- Publication number
- CN114904779A CN114904779A CN202210402927.2A CN202210402927A CN114904779A CN 114904779 A CN114904779 A CN 114904779A CN 202210402927 A CN202210402927 A CN 202210402927A CN 114904779 A CN114904779 A CN 114904779A
- Authority
- CN
- China
- Prior art keywords
- plate
- detection
- workbench
- gasket
- station
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
- 238000001514 detection method Methods 0.000 title claims abstract description 107
- 239000000463 material Substances 0.000 claims abstract description 205
- 230000007246 mechanism Effects 0.000 claims description 96
- 239000000758 substrate Substances 0.000 claims description 10
- 238000007689 inspection Methods 0.000 claims description 7
- 238000007599 discharging Methods 0.000 claims description 4
- 230000003014 reinforcing effect Effects 0.000 claims description 4
- 230000006835 compression Effects 0.000 claims description 2
- 238000007906 compression Methods 0.000 claims description 2
- 230000008878 coupling Effects 0.000 claims description 2
- 238000010168 coupling process Methods 0.000 claims description 2
- 238000005859 coupling reaction Methods 0.000 claims description 2
- 230000002950 deficient Effects 0.000 claims description 2
- 238000012360 testing method Methods 0.000 claims description 2
- 238000004519 manufacturing process Methods 0.000 abstract description 6
- 238000010586 diagram Methods 0.000 description 10
- 230000000712 assembly Effects 0.000 description 9
- 238000000429 assembly Methods 0.000 description 9
- 230000000694 effects Effects 0.000 description 4
- 230000000903 blocking effect Effects 0.000 description 3
- 230000001149 cognitive effect Effects 0.000 description 2
- 238000013101 initial test Methods 0.000 description 1
Images






Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B07—SEPARATING SOLIDS FROM SOLIDS; SORTING
- B07B—SEPARATING SOLIDS FROM SOLIDS BY SIEVING, SCREENING, SIFTING OR BY USING GAS CURRENTS; SEPARATING BY OTHER DRY METHODS APPLICABLE TO BULK MATERIAL, e.g. LOOSE ARTICLES FIT TO BE HANDLED LIKE BULK MATERIAL
- B07B13/00—Grading or sorting solid materials by dry methods, not otherwise provided for; Sorting articles otherwise than by indirectly controlled devices
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B07—SEPARATING SOLIDS FROM SOLIDS; SORTING
- B07B—SEPARATING SOLIDS FROM SOLIDS BY SIEVING, SCREENING, SIFTING OR BY USING GAS CURRENTS; SEPARATING BY OTHER DRY METHODS APPLICABLE TO BULK MATERIAL, e.g. LOOSE ARTICLES FIT TO BE HANDLED LIKE BULK MATERIAL
- B07B13/00—Grading or sorting solid materials by dry methods, not otherwise provided for; Sorting articles otherwise than by indirectly controlled devices
- B07B13/14—Details or accessories
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02P—CLIMATE CHANGE MITIGATION TECHNOLOGIES IN THE PRODUCTION OR PROCESSING OF GOODS
- Y02P90/00—Enabling technologies with a potential contribution to greenhouse gas [GHG] emissions mitigation
- Y02P90/30—Computing systems specially adapted for manufacturing
Landscapes
- Automatic Assembly (AREA)
- Gasket Seals (AREA)
Abstract
The invention relates to an automatic gasket detection machine which is characterized by comprising a rack and a control system, wherein the rack comprises a workbench, a detection platform is arranged in the center of the workbench, and the detection platform is provided with a station to be fed, a detection station and a material distribution station; the automatic feeding device is convenient to operate, replaces manual detection, reduces the labor intensity of workers, improves the detection efficiency, reduces the production cost and ensures the product quality.
Description
Technical Field
The invention relates to detection equipment, in particular to an automatic gasket detection machine.
Background
The gasket is widely applied, the precision requirement of the gasket is high when the gasket is applied to some mechanisms, and full inspection is needed. At present, the detection work is mainly finished by manual detection of operators, the operators detect the gaskets one by one, the detection efficiency is low, the labor intensity is high, the manual operation is tedious, and the conditions of missed detection or cognitive errors are easy to occur, so that the product quality is reduced. In addition, the production batch of the gasket is large, more personnel need to be equipped, and because the current labor cost is continuously increased, the production cost is inevitably increased by manual operation, so that the replacement of the manual operation by an automatic gasket detection machine is inevitable.
Disclosure of Invention
The applicant carries out research and improvement aiming at the problems, provides an automatic gasket detection machine which is convenient to operate, replaces manual detection, lightens the labor intensity of workers, improves the detection efficiency, reduces the production cost and ensures the product quality.
In order to solve the technical problems, the invention adopts the following technical scheme:
an automatic gasket detection machine comprises a machine frame and a control system, wherein the machine frame comprises a workbench, a detection platform is arranged in the center of the workbench, and the detection platform is provided with a material waiting station, a detection station and a material distributing station; the feeding mechanism is arranged on the workbench on one side of the material waiting station, the material moving mechanism is arranged on the workbench on the front side of the detection platform, the detection mechanism is arranged on the workbench at the detection station, the discharging mechanism is arranged on the workbench at the material distributing station, and the material collecting mechanism is arranged on the workbench on one side of the material distributing station;
the feeding mechanism comprises a first support fixedly mounted on the workbench, a substrate is arranged on the first support, 2 manual horizontal sliding tables are symmetrically arranged on two sides of the substrate, 2 support plates are respectively connected with 2 sliding blocks of the manual horizontal sliding tables, V-shaped grooves are respectively formed in the inner side ends of the 2 support plates, 2 oppositely arranged fixed vertical baffles are respectively connected with the 2 support plates through connecting blocks and respectively attached to the outer side surfaces of the V-shaped grooves of the 2 support plates, 2 oppositely arranged movable vertical baffles are respectively connected with the 2 support plates through manual vertical sliding tables and respectively attached to the inner side surfaces of the V-shaped grooves of the 2 support plates, and a gap through which a gasket to be detected can pass is formed between the lower end of each movable vertical baffle and the substrate; the horizontally arranged feeding cylinder is arranged on the first support below the base plate, the horizontally arranged feeding plate is connected with a piston rod of the feeding cylinder through a sliding plate, and a V-shaped groove is formed in the inner side end of the feeding plate; one end of a horizontally arranged guide rod is fixedly connected with the base plate, the section of the guide rod is rectangular, and the sliding plate is provided with a rectangular groove and is connected with the guide rod in a sliding manner;
the material moving mechanism comprises a second support fixedly installed on the workbench, a linear guide rail is arranged on the second support, a horizontally arranged material moving cylinder is arranged on the second support on one side of the linear guide rail, a piston rod of the material moving cylinder is connected with a sliding block of the linear guide rail, a horizontally arranged transverse pushing cylinder is fixedly arranged on the sliding block of the linear guide rail, 2 horizontally arranged material moving plates are connected with the piston rod end of the transverse pushing cylinder, and a semicircular accommodating groove is formed in each material moving plate;
the detection mechanism comprises a lower ejection disc movably embedded in a counter bore at a detection station of the detection platform, a vertical ejection cylinder is arranged on the workbench below the lower ejection disc, a piston rod of the ejection cylinder is connected with the lower ejection disc, and a reset sensor is arranged below the lower ejection disc; the upper ejection disc is coaxially arranged above the lower ejection disc, the upper ejection disc is fixedly connected below the upper mounting plate, the upper mounting plate is fixedly connected with the workbench through a third support, a seat sleeve and an adjusting disc which are coaxially arranged on the upper ejection disc are arranged on the upper mounting plate, the adjusting disc can be rotatably sleeved on the seat sleeve and is fixedly connected with the upper mounting plate through a compression bolt, 4 radial long round holes are symmetrically arranged on the upper mounting plate, 4 spiral slotted holes are symmetrically arranged on the adjusting disc, a sensor chuck is in a waist drum shape with two large ends and two small ends in the middle, axial fractures are arranged on the sensor chuck, 4 vertically arranged detection sensors are respectively clamped in the sensor chuck, and the upper ends and the lower ends of the sensor chuck are respectively slid in the corresponding spiral slotted holes of the adjusting disc and the long round holes of the upper mounting plate, the 4 detection sensors extend to the outer side of the outer circumference of the upper material jacking disk;
a unqualified product box is arranged on the workbench below a material distribution station of the detection platform, a material distribution station of the detection platform is provided with a chute and a blanking hole, a horizontally arranged material distribution plate is slidably mounted in the chute, a material distribution cylinder is fixedly arranged on a fifth support on one side of the material distribution station of the detection platform, the material distribution plate is connected with a piston rod of the material distribution cylinder, and a material baffle plate is arranged above the material distribution plate and is fixedly connected with the detection platform;
during operation, the feeding mechanism sends the gasket to be detected to a material waiting station of the detection platform, the material moving mechanism sends the gasket to be detected to the detection station and the detection mechanism detects the gasket, the detected gasket is sent to a material distributing station by the material moving mechanism, the qualified detected gasket is sent to the material collecting mechanism by the discharging mechanism, and the unqualified detected gasket falls into the unqualified product box.
And further:
the material collecting mechanism comprises a disc-shaped material collecting base which is rotatably arranged on the workbench, and the material collecting base is connected with a stepping motor driving mechanism arranged below the workbench; the material collecting trays are symmetrically and fixedly arranged on the material collecting base and comprise circular bottom plates, 2 radial long round holes are symmetrically formed in the circular bottom plates, and 2 vertical material rods are fixedly connected with the circular bottom plates through the long round holes and bolts; the stepping material supporting mechanism is fixedly arranged below the working table at the material collecting position of the material collecting base and comprises a servo motor ball screw linear sliding table module fixedly connected with the working table, the lower end of a vertically arranged material supporting rod is fixedly connected with a sliding block of the servo motor ball screw linear sliding table module, a cross-shaped bracket is fixedly connected to the upper end of the material supporting rod, a cross-shaped hole through which the cross-shaped bracket can pass is formed in the working table, a cross-shaped hole matched with the cross-shaped bracket is formed in a circular bottom plate of each material collecting tray, and a cross-shaped hole matched with the cross-shaped bracket is formed in the material collecting base below each material collecting tray and is aligned with the cross-shaped hole in the circular bottom plate of the material collecting tray; a proximity sensor is arranged on the workbench on one side of the aggregate base, and a plurality of sensor baffles which correspond to the aggregate trays one by one are fixedly arranged on the outer circumference of the aggregate base; the two sides of the material collecting base at the material collecting position are provided with a pair of photoelectric sensors which are used for detecting whether the material collecting tray is full of gaskets or not.
The collection base is symmetrically provided with 6 collection trays.
Unloading mechanism includes the servo sharp slip table that the level set up, servo sharp slip table passes through fourth support fixed connection the workstation, the lift cylinder fixed connection of perpendicular setting the slider of servo sharp slip table, the lifter plate that the level set up is connected the piston rod of lift cylinder, the suction head adjustment disk of disc pass through dabber rotatable coupling the lifter plate, the symmetry is provided with 3 spiral slotted holes on the suction head adjustment disk, the symmetry is provided with 3 on the lifter plate with the dabber is the radial slotted hole at center, and the axle section of the perpendicular 3 vacuum suction head subassemblies of setting is the sliding sleeve respectively corresponding spiral slotted hole on the suction head adjustment disk reaches in the slotted hole of lifter plate, and the suction head adjustment disk reaches the upper and lower two of lifter plate then are fixed with the nut vacuum suction head subassembly.
The third support below the upper mounting plate of the detection mechanism is provided with a horizontal pushing cylinder, a pushing plate is connected with a piston rod of the pushing cylinder, and the pushing plate extends to a detection station of the detection platform.
And a reinforcing plate is arranged above the feeding plate of the feeding mechanism.
The invention has the technical effects that:
the automatic gasket detection machine disclosed by the invention is convenient to operate, replaces manual detection, reduces the labor intensity of workers, improves the detection efficiency, reduces the production cost and ensures the product quality.
Drawings
FIG. 1 is a schematic three-dimensional structure of the present invention.
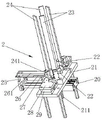
Fig. 2 is a schematic three-dimensional structure diagram of the feeding mechanism.
Fig. 3 is a front view of the feeding mechanism.
Fig. 4 is a cross-sectional view taken at a-a of fig. 3.
Fig. 5 is a schematic three-dimensional structure of the detection mechanism.
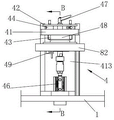
Fig. 6 is a front view of the detection mechanism.
Fig. 7 is a sectional view taken at B-B of fig. 6.
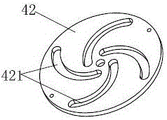
Fig. 8 is a schematic three-dimensional structure diagram of the adjustment disk of the detection mechanism.
Fig. 9 is a schematic three-dimensional structure diagram of an upper mounting plate of the detection mechanism.
Fig. 10 is a schematic three-dimensional structure of a sensor cartridge of the detection mechanism.
Fig. 11 is a three-dimensional structure diagram of the aggregate mechanism.
Fig. 12 is a front view of the aggregate mechanism.
Fig. 13 is a sectional view at C-C of fig. 12.
Fig. 14 is a three-dimensional structure schematic diagram of a stepping material supporting mechanism of the material collecting mechanism.
Fig. 15 is a schematic three-dimensional structure diagram of a material waiting station, a detection station and a material distributing station of the detection platform.
Fig. 16 is a schematic three-dimensional structure diagram of the material moving mechanism.
Fig. 17 is a schematic three-dimensional structure diagram of the blanking mechanism.
Fig. 18 is a schematic three-dimensional structure diagram of a suction head adjusting disc of the blanking mechanism.
Fig. 19 is a schematic three-dimensional structure diagram of the lifting plate of the blanking mechanism.
Detailed Description
The following describes embodiments of the present invention in further detail with reference to the accompanying drawings.
As shown in fig. 1 and 15, the present invention includes a housing 100 and a control system designed and constructed in accordance with the prior art to coordinate the operation of the various components. The rack 100 comprises a workbench 1, a detection platform 8 is arranged in the center of the workbench 1, and the detection platform 8 is provided with a material waiting station 81, a detection station 82 and a material distributing station 83. The feeding mechanism 2 is arranged on the workbench 1 on one side of the material waiting station 81, the material moving mechanism 3 is arranged on the workbench 1 on the front side of the detection platform 8, the detection mechanism 4 is arranged on the workbench 1 at the detection station 82, the discharging mechanism 5 is arranged on the workbench 1 at the material distributing station 83, and the material collecting mechanism 6 is arranged on the workbench 1 on one side of the material distributing station 83.
As shown in fig. 1, 2, 3, and 4, the feeding mechanism 2 includes a first bracket 211 fixedly installed on the working table 1, the substrate 21 is disposed on the first bracket 211, 2 manual horizontal sliding tables 29 are symmetrically disposed on two sides of the substrate 21, 2 support plates 28 are respectively connected to sliders of the 2 manual horizontal sliding tables 29, inner side ends of the 2 support plates 28 are respectively provided with V-shaped grooves, 2 opposite fixed vertical baffles 24 are respectively connected to the 2 support plates 28 through connecting blocks 241 and abut against outer side surfaces of the V-shaped grooves of the 2 support plates 28, 2 opposite movable vertical baffles 23 are respectively connected to the 2 support plates 28 through manual vertical sliding tables 22 and abut against inner side surfaces of the V-shaped grooves of the 2 support plates 28, a lower end of the fixed vertical baffle 24 abuts against the substrate 21, a gap D through which a gasket to be detected can pass is disposed between a lower end of the movable vertical baffle 23 and the substrate 21, an accommodating space through which a gasket to be detected is formed by the 2 fixed vertical baffles 24 and the 2 movable vertical baffles 23, and 2 relative V-arrangement neatly fix an examination gasket by 2 fixed vertical baffle 24 and 2 activity vertical baffle 23 constitutions, examine the gasket through adjusting 2 manual horizontal slip tables 29 with the distance in the horizontal direction between 2 relative fixed vertical baffle 24 and 2 relative activity vertical baffle 23 in order being fit for being used for the gasket of examining of equidimension not, adjust 2 manual vertical slip tables 22 with the clearance D between the lower extreme of adjusting 2 activity vertical baffle 23 and base plate 21, in order to adapt to the gasket of examining of different thickness to pass through, in this embodiment, manual horizontal slip table 29 and manual vertical slip table 22 are the dovetail slip table, for the commodity of market. The horizontally arranged feeding cylinder 20 is arranged on a first support 211 below the base plate 21, the horizontally arranged feeding plate 26 is connected with a piston rod of the feeding cylinder 20 through a sliding plate 25, and a V-shaped groove is formed in the inner side end of the feeding plate 26. One end of a guide rod 27 arranged horizontally is fixedly connected with the base plate 21, the section of the guide rod 27 is rectangular, a rectangular groove is arranged on the sliding plate 25 and is connected with the guide rod 27 in a sliding manner, the feeding plate 26 is driven by the feeding cylinder 20 to reciprocate horizontally, and the guide rod 27 guides the horizontal movement of the feeding plate 26.
During operation, a plurality of gaskets to be detected are horizontally stacked in the accommodating space formed by the 2 fixed vertical baffle plates 24 and the 2 movable vertical baffle plates 23, the feeding cylinder 20 is driven to move each time, the feeding plate 26 is driven to push the lowest gasket to be detected to pass through the gap D between the lower end of the movable vertical baffle plate 23 and the base plate 21, and the gasket to be detected is conveyed to the material waiting station 81 of the detection platform.
In this embodiment, a reinforcing plate 261 is disposed above the feeding plate 26 of the feeding mechanism 2, and since the feeding plate 26 is thin, the reinforcing plate 261 can prevent the feeding plate 26 from deforming only by the thickness of the gasket to be detected.
As shown in fig. 1 and 16, the material transferring mechanism 3 includes a second support 30 fixedly mounted on the workbench 1, a linear guide rail 31 is disposed on the second support 30, a horizontally disposed material transferring cylinder 33 is fixedly disposed on the second support 30 at one side of the linear guide rail 31 through a connecting block 331, a piston rod 33 of the material transferring cylinder is connected to a slider of the linear guide rail 31, a horizontally disposed horizontal pushing cylinder 32 is fixedly disposed on the slider of the linear guide rail 31, 2 horizontally disposed material transferring plates 34 are connected to a piston rod end of the horizontal pushing cylinder 32, and a semicircular accommodating groove 341 is disposed on the material transferring plate 34.
During operation, the piston rod of the transverse pushing cylinder 32 of the material moving mechanism 3 extends out, 2 material moving plates 34 are pushed to the material waiting station 81 and the detection station 82 of the detection platform 8 from the initial position, the 2 material moving plates 34 simultaneously sleeve the gasket to be detected on the material waiting station 81 and the detected gasket on the detection station 82 into the accommodating groove 341 of the 2 material moving plates 34, at this time, the piston rod of the material moving cylinder 33 extends out, the gasket to be detected is transferred to the detection station 82 and the detected gasket is transferred to the material distributing station 83, the piston rod of the transverse pushing cylinder 32 retracts, and then the piston rod of the material moving cylinder 33 retracts, so that the 2 material moving plates 34 return to the initial position.
As shown in fig. 1, 5, 6, 7, 8, 9, 10, and 15, the detecting mechanism 4 includes a lower ejecting disk 45 movably embedded in a counter bore 821 at a detecting station 82 of the detecting platform 8, a vertical ejecting cylinder 46 is disposed on the workbench 1 below the lower ejecting disk 45, a piston rod of the ejecting cylinder 46 is connected to the lower ejecting disk 45, a reset sensor 49 is disposed below the lower ejecting disk 45, the reset sensor 49 is connected to the detecting platform 8 through a bracket, and the reset sensor 49 is used for detecting whether the lower ejecting disk 45 is reset. Go up the coaxial setting of liftout disc 48 in the top of liftout disc 45 down, go up liftout disc 48 fixed connection in the below of last mounting panel 41, go up mounting panel 41 through third support 413 fixed connection workstation 1, the seat cover 40 and the adjustment disk 42 of going up the coaxial setting of liftout disc 48 set up on last mounting panel 41, adjustment disk 42 rotatable suit is on the seat cover 40 and with through clamp bolt 47 fixed connection upper mounting panel 41. The upper mounting plate 41 is symmetrically provided with more than 4 radial long round holes 411 taking the axis of the material ejecting disc 48 as the center, the adjusting plate 42 is symmetrically provided with 4 spiral groove holes 421, the sensor chuck 44 is in a waist drum shape with a large middle and two small ends, the sensor chuck 44 is provided with axial fractures 441, the 4 vertically arranged detection sensors 43 are respectively clamped in the sensor chuck 44 and are pressed by bolts, the shaft sections of the upper and lower ends of the 4 sensor chucks 44 are respectively slid in the corresponding spiral groove holes 421 of the adjusting plate 42 and the long round holes 411 of the upper mounting plate 41, and the 4 detection sensors 43 extend to the outer side of the outer circumference of the material ejecting disc 48. The 4 spiral slots 421 on the adjusting disk 42 cooperate with the 4 oblong holes 411 on the upper mounting plate 41 to synchronously adjust the radial positions of the 4 detection sensors 43 to adapt to the detection of gaskets with different sizes, and during adjustment, the pressing bolt 47 is loosened, and the adjusting disk 42 is rotated, so that the relative positions of the 4 spiral slots 421 on the adjusting disk 42 and the 4 oblong holes 411 on the upper mounting plate 41 are changed, and the radial positions of the 4 detection sensors 43 can be synchronously adjusted.
In operation, the test mechanism 4 is commissioned with standard shims and standard data is read and recorded by the control system prior to the initial test. During detection, the material moving mechanism 3 moves the gasket to be detected to the lower ejection disc 45 of the detection mechanism 4, the piston rod of the ejection cylinder 46 extends out, the lower ejection disc 45 rises and ejects and compresses the gasket to be detected between the lower ejection disc 45 and the upper ejection disc 48, the detection data of the 4 detection sensors 43 are transmitted to the control system, the detection data are compared with the standard data, the judgment result is that the gasket is qualified when the gasket is within a tolerance range, and the judgment result is that the gasket is unqualified when the gasket is out of the tolerance range. After detection is finished, the lower ejection disc 45 resets, and the material moving mechanism 3 transfers the detected gaskets to the material distributing station 83 for distributing materials.
In this embodiment, a horizontal pushing cylinder 412 is disposed on a third bracket 413 below the upper mounting plate 41 of the detecting mechanism 4, the pushing plate 410 is connected to a piston rod of the pushing cylinder 412, and the pushing plate 410 extends to the detecting station 82 of the detecting platform 8. When gaskets to be detected with different sizes are detected in a changing mode, when the gaskets to be detected cannot be conveyed to the center of the lower ejection disc 45 on the detection station 82 of the detection platform 8, a material pushing action can be added in the control system, and the material pushing cylinder 412 drives the material pushing plate 410 to push the gaskets to be detected to the center of the lower ejection disc 45.
As shown in fig. 1 and 15, a defective product box 7 is disposed on the worktable 1 below the material distribution station 83 of the detection platform 8, a chute 93 and a blanking hole 94 are disposed at the material distribution station 83 of the detection platform, a horizontally disposed material distribution plate 91 is slidably mounted in the chute 93, a material distribution cylinder 95 is fixedly disposed on a fifth support 96 at one side of the material distribution station 83 of the detection platform 8, the material distribution plate 91 is connected to a piston rod of the material distribution cylinder 95, and a material blocking plate 92 is disposed above the material distribution plate 91 and is fixedly connected to the detection platform 8.
In the initial state, the material distributing plate 91 is in the chute 93 of the material distributing station 83 and covers the blanking hole 94 above the unqualified product box 7, at this time, the piston rod of the material distributing cylinder 95 is in the extending state, the inspected gasket detected by the detection mechanism 4 is transferred to the material distributing plate 91 by the material transferring mechanism 3, the qualified inspected gasket is transferred to the material collecting mechanism 6 by the blanking mechanism 5, when the unqualified inspected gasket is transferred to the material distributing plate 91, the piston rod of the material distributing cylinder 95 retracts and drives the material distributing plate 91 to move out of the chute 93, due to the blocking effect of the material blocking plate 92, the unqualified inspected gasket falls into the unqualified product box 7 through the blanking hole 94, and the material distributing cylinder 95 and the material distributing plate 91 return to the initial state again.
As shown in fig. 1, 11, 12, 13, and 14, the collecting mechanism 6 includes a disc-shaped collecting base 61 rotatably disposed on the working table 1, the collecting base 61 is connected to a stepping motor driving mechanism 66 disposed below the working table 1, 6 collecting trays 60 are symmetrically and fixedly disposed on the collecting base 61, each collecting tray 60 includes a circular bottom plate 601, 2 radial oblong holes 603 are symmetrically disposed on the circular bottom plate 601, 2 vertical material rods 602 are fixedly connected to the circular bottom plate 601 through the oblong holes 603 and bolts, and the oblong holes 603 can conveniently adjust the radial positions of the 2 vertical material rods 602 to adapt to gaskets of different sizes. The fixed workstation 1 that sets up the below of the position department that gathers materials of base 61 that gathers materials of step-by-step material supporting mechanism, step-by-step material supporting mechanism includes servo motor ball screw straight line slip table module 69 of fixed connection workstation 1, the perpendicular lower extreme fixed connection servo motor ball screw straight line slip table module 69 of material support pole 68 that sets up, cross bracket 64 fixed connection is in the upper end of material support pole 68, the position department of gathering materials on workstation 1 is equipped with the cross hole that can supply cross bracket 64 to pass through, be equipped with the cross hole 604 that matches with cross bracket 64 on the circular bottom plate 601 of tray 60 that gathers materials, the base 61 that gathers materials under every tray 60 that gathers materials is equipped with the cross hole that matches with cross bracket 64 and aligns with the cross hole on the circular bottom plate 601 of tray 60 that gathers materials. When the material is collected, the next empty material collecting tray 60 is driven by the stepping motor driving mechanism 66 to stop at the material collecting position, the servo motor ball screw linear sliding table module 69 of the stepping material supporting mechanism drives the cross bracket 64 to ascend, the cross bracket 64 penetrates through a cross hole at the material collecting position on the workbench 1, a cross hole on the material collecting base 61 and a cross hole 604 on a circular bottom plate 601 of the material collecting tray 60 and ascends to be close to the top ends of 2 material rods 602, when the material is collected, the qualified detected gasket is transferred to the cross bracket 64 from the material distributing position 83 by the blanking mechanism 5, an inner hole of the detected gasket is sleeved into the 2 material rods 602, and when the blanking mechanism 5 conveys one qualified detected gasket, the servo motor ball screw linear sliding table module 69 of the stepping material supporting mechanism drives the cross bracket 64 to descend by the thickness of one gasket until one material collecting tray 60 is full; the servo motor ball screw linear sliding table module 69 of the stepping material supporting mechanism drives the cross bracket 64 to continuously descend to the cross hole at the material collecting position on the workbench 1, and the stepping motor driving mechanism 66 drives the material collecting base 61 to rotate clockwise, so that the next empty material collecting tray 60 stops at the material collecting position and enters the next material collecting cycle. The material collecting base 61 is provided with a proximity sensor 63 on the workbench 1 on one side, 6 sensor baffles 62 which are in one-to-one correspondence with the material collecting trays 60 are fixedly arranged on the outer circumference of the material collecting base 61, the sensor baffles 62 and the proximity sensor 63 are used for ensuring that each empty material collecting tray 60 is accurately stopped at a material collecting position, when one material collecting tray 60 is full of the inspected gasket, the stepping motor driving mechanism 66 drives the material collecting base 61 to rotate, and when the next sensor baffle 62 rotates to be aligned with the proximity sensor 63, the stepping motor driving mechanism 66 stops to stop the next empty material collecting tray 60 at the material collecting position. A pair of photoelectric sensors 65 for detecting whether the gaskets are fully collected on the material collecting tray 60 are arranged on the working tables 1 on two sides of the material collecting base 61 at the material collecting position. When the empty material collecting tray 60 enters the material collecting position, the photoelectric sensor 65 feeds back a signal to the control system to continue the material collecting action; when the material collecting tray 60 full of gaskets enters the material collecting position, the photoelectric sensor 65 feeds back a signal to the control system to stop the material collecting action and give an alarm to inform an operator to take away the detected gaskets.
As shown in fig. 1, 17, 18 and 19, the blanking mechanism 5 comprises a horizontally arranged servo linear sliding table 55, the servo linear sliding table 55 is fixedly connected with the worktable 1 through a fourth bracket 50, a vertically arranged lifting cylinder 54 is fixedly connected with a slide block of the servo linear sliding table 55, a horizontally arranged lifting plate 53 is connected with a piston rod of the lifting cylinder 54, a disc-shaped suction head adjusting disc 52 is rotatably connected with the lifting plate 53 through a mandrel, 3 spiral slotted holes 521 are symmetrically arranged on the suction head adjusting disc 52, 3 radial long round holes 531 with the mandrel as the center are symmetrically arranged on the lifting plate 53, shaft sections of the vertically arranged 3 vacuum suction head assemblies 51 are respectively slid in the spiral slotted holes 521 on the corresponding suction head adjusting disc 52 and the long round holes 531 of the lifting plate 53, and the vacuum suction head assemblies 51 are fixed on the upper and lower sides of the suction head adjusting disc and the lifting plate by nuts, the vacuum suction head assemblies 51 are connected with a vacuum generator, for sucking and releasing the gasket.
The radial positions of 3 vacuum sucker assemblies 51 can be synchronously adjusted by 3 spiral slotted holes 521 on the sucker adjusting disc 52 and 3 long round holes 531 on the lifting plate 53 so as to be suitable for sucking and transferring gaskets with different sizes, and during adjustment, nuts are loosened, and the sucker adjusting disc 52 is rotated, so that the relative positions of the 3 spiral slotted holes 521 on the sucker adjusting disc 52 and the 3 long round holes 531 on the lifting plate 53 are changed, and the radial positions of the 3 vacuum sucker assemblies 51 can be synchronously adjusted. When the blanking operation is carried out, the servo linear sliding table 55 drives the 3 vacuum sucker assemblies 51 to move to the material distribution station 83 of the detection platform 8, the lifting cylinder 54 drives the 3 vacuum sucker assemblies 51 to descend and suck qualified inspected gaskets, the lifting cylinder 54 drives the 3 vacuum sucker assemblies 51 and the sucked qualified inspected gaskets to ascend, the servo linear sliding table 55 drives the 3 vacuum sucker assemblies 51 and the sucked qualified inspected gaskets to move to the material collection mechanism 6, the qualified inspected gaskets are released, and the primary blanking operation is completed.
When the automatic gasket detection operation is carried out, the gasket to be detected is conveyed to a material waiting station 81 of a detection platform 8 by a feeding mechanism 2, the gasket to be detected is conveyed to a detection station 82 by a material moving mechanism 3 and is detected by a detection mechanism 4, the detected gasket is conveyed to a material distribution station 83 by the material moving mechanism 3, the qualified detected gasket is conveyed to a material collecting mechanism 6 by a blanking mechanism 5, and the unqualified detected gasket falls into an unqualified product box 7. The invention has convenient operation, replaces manual detection, lightens the labor intensity of workers, improves the detection efficiency, reduces the number of operators, reduces errors caused by missed detection or cognitive errors, reduces the production cost and ensures the product quality.
Claims (6)
1. The utility model provides a gasket automated inspection machine which characterized in that: the automatic feeding device comprises a rack and a control system, wherein the rack comprises a workbench, a detection platform is arranged in the center of the workbench, and the detection platform is provided with a material waiting station, a detection station and a material distributing station; the feeding mechanism is arranged on the workbench on one side of the material waiting station, the material moving mechanism is arranged on the workbench on the front side of the detection platform, the detection mechanism is arranged on the workbench at the detection station, the discharging mechanism is arranged on the workbench at the material distributing station, and the material collecting mechanism is arranged on the workbench on one side of the material distributing station;
the feeding mechanism comprises a first support fixedly mounted on the workbench, a substrate is arranged on the first support, 2 manual horizontal sliding tables are symmetrically arranged on two sides of the substrate, 2 support plates are respectively connected with 2 sliding blocks of the manual horizontal sliding tables, V-shaped grooves are respectively formed in the inner side ends of the 2 support plates, 2 oppositely arranged fixed vertical baffles are respectively connected with the 2 support plates through connecting blocks and respectively attached to the outer side surfaces of the V-shaped grooves of the 2 support plates, 2 oppositely arranged movable vertical baffles are respectively connected with the 2 support plates through manual vertical sliding tables and respectively attached to the inner side surfaces of the V-shaped grooves of the 2 support plates, and a gap through which a gasket to be detected can pass is formed between the lower end of each movable vertical baffle and the substrate; the horizontally arranged feeding cylinder is arranged on the first support below the base plate, the horizontally arranged feeding plate is connected with a piston rod of the feeding cylinder through a sliding plate, and a V-shaped groove is formed in the inner side end of the feeding plate; one end of a horizontally arranged guide rod is fixedly connected with the base plate, the section of the guide rod is rectangular, and the sliding plate is provided with a rectangular groove and is connected with the guide rod in a sliding manner;
the material moving mechanism comprises a second support fixedly installed on the workbench, a linear guide rail is arranged on the second support, a horizontally arranged material moving cylinder is arranged on the second support on one side of the linear guide rail, a piston rod of the material moving cylinder is connected with a sliding block of the linear guide rail, a horizontally arranged transverse pushing cylinder is fixedly arranged on the sliding block of the linear guide rail, 2 horizontally arranged material moving plates are connected with the piston rod end of the transverse pushing cylinder, and a semicircular accommodating groove is formed in each material moving plate;
the detection mechanism comprises a lower ejection disc movably embedded in a counter bore at a detection station of the detection platform, a vertical ejection cylinder is arranged on the workbench below the lower ejection disc, a piston rod of the ejection cylinder is connected with the lower ejection disc, and a reset sensor is arranged below the lower ejection disc; the upper ejection disc is coaxially arranged above the lower ejection disc, the upper ejection disc is fixedly connected below the upper mounting plate, the upper mounting plate is fixedly connected with the workbench through a third support, a seat sleeve and an adjusting disc which are coaxially arranged on the upper ejection disc are arranged on the upper mounting plate, the adjusting disc can be rotatably sleeved on the seat sleeve and is fixedly connected with the upper mounting plate through a compression bolt, 4 radial long round holes are symmetrically arranged on the upper mounting plate, 4 spiral slotted holes are symmetrically arranged on the adjusting disc, a sensor chuck is in a waist drum shape with two large ends and two small ends in the middle, axial fractures are arranged on the sensor chuck, 4 vertically arranged detection sensors are respectively clamped in the sensor chuck, and the upper ends and the lower ends of the sensor chuck are respectively slid in the corresponding spiral slotted holes of the adjusting disc and the long round holes of the upper mounting plate, the 4 detection sensors extend to the outer side of the outer circumference of the upper material jacking disk;
a unqualified product box is arranged on the workbench below a material distribution station of the detection platform, a chute and a blanking hole are formed in the material distribution station of the detection platform, a horizontally arranged material distribution plate is slidably mounted in the chute, a material distribution cylinder is fixedly arranged on a fifth support on one side of the material distribution station of the detection platform, the material distribution plate is connected with a piston rod of the material distribution cylinder, and a material baffle plate is arranged above the material distribution plate and is fixedly connected with the detection platform;
during operation, feed mechanism will wait to examine the gasket and deliver to testing platform's the station of waiting to expect, by move material mechanism will wait to examine the gasket and deliver to the detection station, and by detection mechanism detects, examined the gasket again by move material mechanism and deliver to dividing the material station, qualified examined the gasket by unloading mechanism delivers to gather materials the mechanism, unqualified examined the gasket falls into the defective products case.
2. The gasket automated inspection machine of claim 1, wherein: the material collecting mechanism comprises a disc-shaped material collecting base which is rotatably arranged on the workbench, and the material collecting base is connected with a stepping motor driving mechanism arranged below the workbench; the material collecting trays are symmetrically and fixedly arranged on the material collecting base and comprise circular bottom plates, 2 radial long round holes are symmetrically formed in the circular bottom plates, and 2 vertical material rods are fixedly connected with the circular bottom plates through the long round holes and bolts; the stepping material supporting mechanism is fixedly arranged below the working table at the material collecting position of the material collecting base and comprises a servo motor ball screw linear sliding table module fixedly connected with the working table, the lower end of a vertically arranged material supporting rod is fixedly connected with a sliding block of the servo motor ball screw linear sliding table module, a cross bracket is fixedly connected to the upper end of the material supporting rod, the working table is provided with a cross hole through which the cross bracket can pass, a circular bottom plate of the material collecting tray is provided with a cross hole matched with the cross bracket, and the material collecting base below each material collecting tray is provided with a cross hole matched with the cross bracket and aligned with the cross hole on the circular bottom plate of the material collecting tray; a proximity sensor is arranged on the workbench on one side of the aggregate base, and a plurality of sensor baffles which are in one-to-one correspondence with the aggregate trays are fixedly arranged on the outer circumference of the aggregate base; and a pair of photoelectric sensors for detecting whether the material collecting tray is full of gaskets or not are arranged on the workbench on the two sides of the material collecting base at the material collecting position.
3. The gasket automated inspection machine of claim 2, wherein: the collection base is symmetrically provided with 6 collection trays.
4. The gasket automated inspection machine of claim 1, wherein: unloading mechanism includes the servo sharp slip table that the level set up, servo sharp slip table passes through fourth support fixed connection the workstation, the lift cylinder fixed connection of perpendicular setting the slider of servo sharp slip table, the lifter plate that the level set up is connected the piston rod of lift cylinder, the suction head adjustment disk of disc pass through dabber rotatable coupling the lifter plate, the symmetry is provided with 3 spiral slotted holes on the suction head adjustment disk, the symmetry is provided with 3 on the lifter plate with the dabber is the radial slotted hole at center, and the axle section of the perpendicular 3 vacuum suction head subassemblies of setting is the sliding sleeve respectively corresponding spiral slotted hole on the suction head adjustment disk reaches in the slotted hole of lifter plate, and the suction head adjustment disk reaches the upper and lower two of lifter plate then are fixed with the nut vacuum suction head subassembly.
5. The gasket automated inspection machine of claim 1, wherein: the third support below the upper mounting plate of the detection mechanism is provided with a horizontal pushing cylinder, a pushing plate is connected with a piston rod of the pushing cylinder, and the pushing plate extends to a detection station of the detection platform.
6. The gasket automated inspection machine of claim 1, wherein: and a reinforcing plate is arranged above the feeding plate of the feeding mechanism.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202210402927.2A CN114904779B (en) | 2022-04-18 | 2022-04-18 | Automatic gasket detection machine |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202210402927.2A CN114904779B (en) | 2022-04-18 | 2022-04-18 | Automatic gasket detection machine |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN114904779A true CN114904779A (en) | 2022-08-16 |
| CN114904779B CN114904779B (en) | 2023-05-23 |
Family
ID=82764946
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202210402927.2A Active CN114904779B (en) | 2022-04-18 | 2022-04-18 | Automatic gasket detection machine |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN114904779B (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN117798625A (en) * | 2024-01-03 | 2024-04-02 | 科顺防水科技股份有限公司 | Anchor assembly device |
| CN118023463A (en) * | 2024-01-09 | 2024-05-14 | 宁波元鼎智能科技有限公司 | Hinge riveting mechanism with automatic screening function |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20040007442A1 (en) * | 2002-07-12 | 2004-01-15 | Marchesini Group S.P.A. | Method and apparatus for selecting and feeding articles |
| US20090255854A1 (en) * | 2008-04-02 | 2009-10-15 | Bazinet Dominic | Apparatus and method for recuperating objects from a mixture |
| CN104907225A (en) * | 2015-06-17 | 2015-09-16 | 肖根福罗格注胶技术(苏州工业园区)有限公司 | Automatic turntable glue injection system and glue injection detection method thereof |
| CN108372132A (en) * | 2018-04-25 | 2018-08-07 | 国泰精密机件(无锡)有限公司 | A kind of defective work detects separator automatically |
| CN108994186A (en) * | 2018-09-27 | 2018-12-14 | 无锡永凯达齿轮有限公司 | Automobile belt Radspanner automatic assembling and the special plane examined |
-
2022
- 2022-04-18 CN CN202210402927.2A patent/CN114904779B/en active Active
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20040007442A1 (en) * | 2002-07-12 | 2004-01-15 | Marchesini Group S.P.A. | Method and apparatus for selecting and feeding articles |
| US20090255854A1 (en) * | 2008-04-02 | 2009-10-15 | Bazinet Dominic | Apparatus and method for recuperating objects from a mixture |
| CN104907225A (en) * | 2015-06-17 | 2015-09-16 | 肖根福罗格注胶技术(苏州工业园区)有限公司 | Automatic turntable glue injection system and glue injection detection method thereof |
| CN108372132A (en) * | 2018-04-25 | 2018-08-07 | 国泰精密机件(无锡)有限公司 | A kind of defective work detects separator automatically |
| CN108994186A (en) * | 2018-09-27 | 2018-12-14 | 无锡永凯达齿轮有限公司 | Automobile belt Radspanner automatic assembling and the special plane examined |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN117798625A (en) * | 2024-01-03 | 2024-04-02 | 科顺防水科技股份有限公司 | Anchor assembly device |
| CN118023463A (en) * | 2024-01-09 | 2024-05-14 | 宁波元鼎智能科技有限公司 | Hinge riveting mechanism with automatic screening function |
| CN118023463B (en) * | 2024-01-09 | 2025-12-12 | 浙江君睿智能装备有限公司 | A hinge riveting mechanism with automatic screening function |
Also Published As
| Publication number | Publication date |
|---|---|
| CN114904779B (en) | 2023-05-23 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110038816B (en) | Piston rod vortex flaw detector | |
| CN110653177B (en) | Automatic detection equipment and detection method for mobile phone screen | |
| CN110125026B (en) | Thickness measuring equipment | |
| CN109848678A (en) | A kind of automatic assembling copper sheathing equipment | |
| CN214391171U (en) | Resistor resistance value testing and sorting tool | |
| CN113663939B (en) | Automatic electrical measuring machine | |
| CN114589481B (en) | High-precision heat radiation module nut riveting equipment | |
| CN116809432A (en) | A kind of roller automatic detection device | |
| CN111422613A (en) | Spline check out test set | |
| CN222885710U (en) | Commutator automatic testing machine | |
| CN114904779B (en) | Automatic gasket detection machine | |
| CN110757155B (en) | Automatic crimping machine for ladle needle | |
| CN218973829U (en) | Automatic change coil motor detection performance device | |
| CN113664497B (en) | Focusing device holds carrier equipment check out test set | |
| CN213934073U (en) | Circulator vector net testing machine | |
| CN210358132U (en) | Thickness measuring equipment | |
| CN110434801B (en) | Automatic lamination equipment of aluminum sheet and rubber ring for block | |
| CN212120862U (en) | Size detection machine for metal parts | |
| CN109108761B (en) | Circular tube feeding and guiding method for precision part welding center | |
| CN117735240A (en) | Material classifying and stacking device | |
| CN212872726U (en) | Full-automatic product detection equipment | |
| CN217919993U (en) | Stock bin type arrangement machine | |
| CN112697791B (en) | Detection equipment of USB terminal | |
| CN216645764U (en) | Elastic sheet elasticity and angle testing machine | |
| CN211589566U (en) | Slip sheet polishing equipment |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |