Cantilever type pipeline dredging vehicle and working method
Technical Field
The invention relates to the field of urban pipe network dredging equipment, in particular to an arm support type pipeline dredging vehicle.
Background
The bottom of an urban sewer inspection well generates siltation, and a crane steel wire rope grab bucket truck or an excavating type hard arm grab bucket truck is used in the current general method. When the crane steel wire rope grab bucket vehicle is used for operation, the grab bucket is used for grabbing sludge by means of the self weight of the grab bucket, and the sludge cannot go deep into the sludge deep position to grab when the sludge is hardened seriously. And use to dig and draw formula hard arm grab bucket and through the decurrent pressure of forcing, impress the grab bucket sediment depths and snatch, but the forms such as four-bar linkage, tilting mechanism are adopted more in the middle of this kind of form, and the mechanism action is many in the operation process, snatchs, unloads and needs a plurality of actions just can accomplish the operation, and the operating efficiency is low, poor stability. Some manufacturers adopt a module control system to carry out memory positioning to provide efficiency, but the problems of high requirement on operators, high failure rate and the like are brought.
Therefore, the development of a novel dredging grab bucket vehicle becomes one of the problems to be solved urgently in the field.
Disclosure of Invention
The invention aims to provide an arm support type pipeline dredging vehicle and a working method, which aim to solve the problems in the prior art.
In order to achieve the purpose, the invention provides the following technical scheme:
the utility model provides an arm support formula pipeline dredging vehicle, includes the dredging vehicle chassis, install control system, tipping bucket carriage and hydraulic leg on the dredging vehicle chassis, the last rotatory stand that is equipped with of control system, the swinging boom is installed to the top of rotatory stand, flexible arm is installed to the top of swinging boom, the grab bucket is installed to the end of flexible arm.
Furthermore, the rotating upright column comprises an upright column rotary drive and a rotating upright column frame arranged on the upright column rotary drive, and the rotating upright column frame is rotated through the rotation of the upright column rotary drive.
The rotating arm comprises a rotating arm rotary drive, a rotating arm support and a turnover oil cylinder, wherein the rotating arm and the turnover oil cylinder are mounted on the rotating arm rotary drive, and the rotating arm support rotates through rotation of the rotating arm rotary drive.
Furthermore, the overturning oil cylinder comprises an overturning oil cylinder outer cylinder and an overturning oil cylinder rod arranged in the overturning oil cylinder outer cylinder, the head of the overturning oil cylinder outer cylinder is arranged on one section of arm of the telescopic arm, the rod head of the overturning oil cylinder rod is arranged on the head of the rotary arm frame, and the telescopic arm is overturned through the stretching of the oil cylinder.
Furthermore, the telescopic arm comprises a first-section arm, a second-section arm arranged in the first-section arm, a third-section arm arranged in the second-section arm and a fourth-section arm arranged in the third-section arm, a hydraulic reel is arranged at the tail of the first-section arm, telescopic oil cylinders are connected to the outer side of the first-section arm and the outer side of the second-section arm respectively, a grab bucket rotator is arranged at the head of the fourth-section arm, a grab bucket is arranged at the head of the grab bucket rotator, and linkage steel wire ropes are arranged among the second-section arm, the third-section arm and the fourth-section arm to realize multi-arm stretching.
The telescopic oil cylinder comprises a telescopic oil cylinder outer cylinder and a telescopic oil cylinder rod, the telescopic oil cylinder outer cylinder is connected with the first section of arm, the telescopic oil cylinder rod is connected with the second section of arm, and the telescopic arm is stretched through stretching of the telescopic oil cylinder.
The grab bucket rotator is arranged between the four-section arm and the grab bucket, and the grab bucket rotates 360 degrees through the rotation of the grab bucket rotator.
The grab bucket comprises a grab bucket oil cylinder outer cylinder, a grab bucket oil cylinder rod is arranged in the grab bucket oil cylinder outer cylinder, a grab bucket adjusting rod is arranged on the outer ear of the grab bucket oil cylinder outer cylinder, the grab bucket oil cylinder outer cylinder and the grab bucket adjusting rod are both connected with a grab bucket grab sheet, and the grab bucket grab sheet is opened and closed through the stretching of the oil cylinder.
The sensor is arranged on the outer side of the column rotary drive of the rotary column and the outer side of the rotary arm rotary drive of the rotary arm, and the sensor is connected with the control system through a cable.
Furthermore, the hydraulic support legs are installed on a chassis of the dredging vehicle at the rear part of the cab, and the control system controls the support legs to stretch.
The working method of the cantilever type pipeline dredging vehicle specifically comprises the following steps:
the process of converting the running state into the construction preparation state is that the hydraulic support legs are controlled to extend out through the control system to support the ground, so that the chassis of the dredging vehicle is in a horizontal support state; then, the control system controls the overturning oil cylinder to enable the telescopic arm to be converted from a horizontal state to a vertical state;
according to the position of the well mouth of the inspection well, the upright post rotary drive and the rotary arm rotary drive are controlled to rotate through a control system, so that the rotary arm frame is driven to rotate, and the telescopic arm is vertically positioned right above the well mouth of the inspection well through two rotations;
the control system controls the telescopic action of the telescopic oil cylinder, after the telescopic arm extends out, the head of the grab bucket reaches the bottom of the inspection well, the grab bucket cylinder rod extends out of the outer cylinder of the grab bucket cylinder, the grab bucket grab blade hinged with the grab bucket adjusting rod and the grab bucket cylinder rod starts to be opened, then the grab bucket cylinder rod retracts into the outer cylinder of the grab bucket cylinder, and the grab bucket grab blade hinged with the grab bucket adjusting rod and the grab bucket cylinder rod starts to be closed to grab sediments;
the control system controls the grab bucket oil cylinder rod to perform an opposite process on the outer cylinder of the grab bucket oil cylinder and the telescopic oil cylinder, so that sludge is taken out of a well mouth;
the control system controls the rotating arm to rotate in a rotary driving mode, so that the telescopic arm is driven to be above the tipping wagon compartment;
hydraulic oil is controlled by a control system to be conveyed to a control grab bucket oil cylinder rod on the outer cylinder of the grab bucket oil cylinder through a hydraulic scroll, the grab bucket oil cylinder rod extends out of the outer cylinder of the grab bucket oil cylinder, and a grab bucket grab blade is opened for discharging; when the grabbing cycle is finished, the next grabbing cycle can be started, and the grab bucket rotator can be controlled by the control system to realize the rotation angle of the grab bucket according to the bottom hole condition, so that the bottom hole can be grabbed cleanly;
after the operation is finished, the control system carries out reverse operation to control the overturning oil cylinder, so that the telescopic arm is converted into a horizontal state from a vertical state, and the hydraulic support leg is controlled to retract.
Compared with the prior art, the invention has the beneficial effects that:
the cantilever type pipeline dredging vehicle can grab the sludge in the inspection well into the tipping bucket carriage through simple rotary telescopic action. A upset action gets into operating condition, can aim at the well head through two rotation movements, and the operation only needs a rotation at the back, and desilting operation can be accomplished to flexible one, and operating personnel only need carry out simple training and can go on duty. The whole mechanism has the advantages of ingenious structure, simple action, small jitter and high reliability.
Drawings
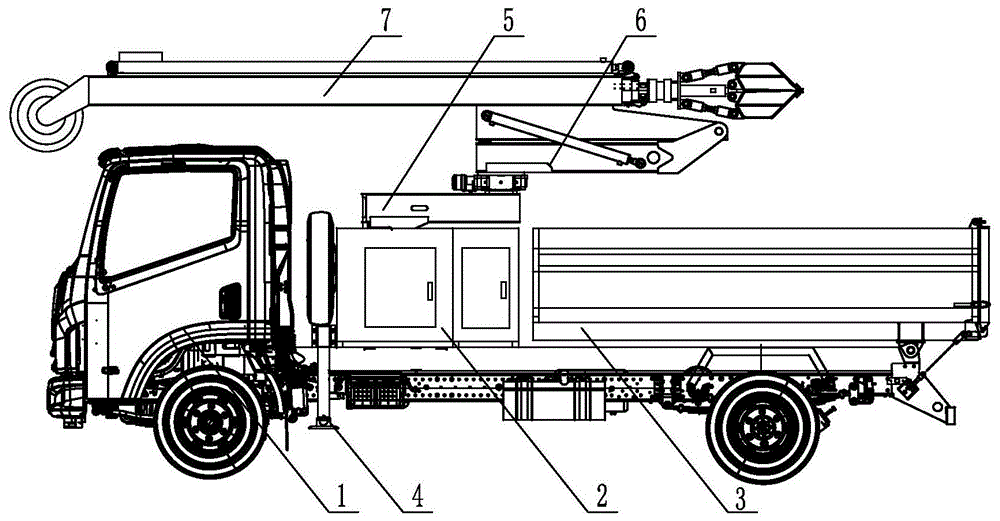
FIG. 1 is a schematic front view of the whole structure of the boom type pipeline dredging vehicle of the present invention;
FIG. 2 is a schematic plan view of the entire structure of the boom-type pipeline dredging vehicle of the present invention;
FIG. 3 is a schematic structural view of a rotary column, a rotary arm and a telescopic arm according to the present invention;
FIG. 4 is a schematic view of the telescopic arm of the present invention;
fig. 5 to 8 are schematic views of the working state of the cantilever-type pipeline dredging vehicle of the invention.
Wherein, 1-a chassis of the desilting vehicle; 2-a control system; 3-tipping body; 4-hydraulic support legs; 5-rotating the upright post; 51-column rotation driving; 52-rotating column frame; 6-rotating arm; 61-rotary arm rotary drive; 62-rotating the arm support; 63-overturning the oil cylinder; 631-overturning the outer cylinder of the oil cylinder; 632-tilt cylinder rod; 7-a telescopic arm; 71-one arm; 72-two-section arm; 73-three section arm; 74-four-section arm; 75-a hydraulic reel; 76-a telescopic oil cylinder; 761-outer cylinder of telescopic cylinder; 762-telescoping cylinder rod; 77-grab bucket rotator; 78-grab bucket; 781-grab bucket cylinder outer cylinder; 782-grab bucket cylinder rod; 783-grab bucket adjusting rod; 784-grab bucket grab blade; 79-linkage wire rope.
Detailed Description
The technical solutions in the embodiments of the present invention will be clearly and completely described below, and it is obvious that the described embodiments are only a part of the embodiments of the present invention, and not all embodiments. All other embodiments, which can be derived by a person skilled in the art from the embodiments given herein without making any creative effort, shall fall within the protection scope of the present invention.
As shown in fig. 1-3, the boom type pipeline dredging vehicle of the invention comprises a dredging vehicle chassis 1, a control system 2, a tipping wagon 3, hydraulic support legs 4, a rotating upright post 5, a rotating arm 6 and a telescopic arm 7, wherein the control system 2 is arranged at the middle front part of the dredging vehicle chassis 1, the tipping wagon 3 is arranged at the rear part of the dredging vehicle chassis 1, the hydraulic support legs 4 are arranged at the middle front part of the dredging vehicle chassis 1 (the front part of the control system 2 and the rear part of a cab), the rotating upright post 5 is arranged at the inner side of the control system 2, the rotating arm 6 is arranged above the rotating upright post 5, and the telescopic arm 7 is arranged above the rotating arm 6. A grab bucket 78 is mounted at the end of the telescopic arm 7.
The rotary column 5 includes a column swing drive 51 and a rotary column holder 52 attached to the column swing drive 51, and the rotation of the rotary column holder 52 is realized by the rotation of the column swing drive 51.
The rotating arm 6 comprises a rotating arm rotary drive 61, and a rotating arm support 62 and a turnover oil cylinder 63 which are arranged on the rotating arm rotary drive 61, and the rotation of the rotating arm support 62 is realized through the rotation of the rotating arm rotary drive 61.
The overturning oil cylinder 63 comprises an overturning oil cylinder outer cylinder 631 and an overturning oil cylinder rod 632 arranged in the overturning oil cylinder outer cylinder 631, the head of the overturning oil cylinder outer cylinder 631 is arranged on one section of arm 71 of the telescopic arm 7, the head of the overturning oil cylinder rod 632 is arranged on the head of the rotary arm support 62, and the telescopic arm 7 is overturned through the expansion and contraction of the oil cylinder.
The telescopic arm 7 comprises a first-section arm 71, a second-section arm 72 arranged in the first-section arm 71, a third-section arm 73 arranged in the second-section arm 72 and a fourth-section arm 74 arranged in the third-section arm 73, wherein a hydraulic reel 75 is arranged at the tail part of the first-section arm 71, telescopic oil cylinders 76 are connected to the outer side of the first-section arm 71 and the outer side of the second-section arm 72 respectively, a grab bucket rotator 77 is arranged at the head part of the fourth-section arm 74, a grab bucket 78 is arranged at the head part of the grab bucket rotator 77, and linkage steel cables 79 are arranged among the second-section arm 72, the third-section arm 73 and the fourth-section arm 74 to realize multi-arm telescopic.
The telescopic oil cylinder 76 comprises a telescopic oil cylinder outer cylinder 761 and a telescopic oil cylinder rod 762, the telescopic oil cylinder outer cylinder 761 is connected with the first section of arm 71, the telescopic oil cylinder rod 762 is connected with the second section of arm 72, and the telescopic arm 7 is telescopic through the telescopic effect of the telescopic oil cylinder 76.
The grapple rotator 77 is installed between the four-joint arm 74 and the grapple 78, and 360 ° rotation of the grapple 78 is achieved by rotation of the grapple rotator 77.
The grab bucket 78 comprises a grab bucket oil cylinder outer cylinder 781, a grab bucket oil cylinder rod 782 is arranged in the grab bucket oil cylinder outer cylinder 781, a grab bucket adjusting rod 783 is arranged on the outer ear of the grab bucket oil cylinder outer cylinder 781, the grab bucket oil cylinder outer cylinder 781 and the grab bucket adjusting rod 783 are both connected with a grab bucket grab sheet 784, and the grab bucket grab sheet 784 is opened and closed through the stretching of the oil cylinders.
The working method of the cantilever type pipeline dredging vehicle specifically comprises the following steps:
referring to fig. 5, the process of the boom type pipeline dredging vehicle of the present invention converting from the driving state to the construction preparation state is that the control system 2 controls the hydraulic legs 4 to extend out to support the ground, so that the chassis 1 of the dredging vehicle is in the horizontal support state. Then, the control system 2 controls the overturning oil cylinder 63 to convert the telescopic arm 7 from the horizontal state to the vertical state.
As shown in fig. 6, according to the position of the manhole, the control system 2 controls the rotation of the column slewing drive 51 and the rotating arm slewing drive 61, the rotating column frame 52 is mounted on the rotating flange of the column slewing drive 51, so as to drive the rotating column frame 52 to rotate, the rotating arm frame 62 is mounted on the rotating flange of the rotating arm slewing drive 61, so as to drive the rotating arm frame 62 to rotate, the telescopic arm 7 is mounted above the rotating arm 6, so that the telescopic arm 7 is vertically positioned right above the manhole through two rotations.
As shown in fig. 4 and 7, the control system 2 controls the telescopic operation of the telescopic cylinder 76, the telescopic cylinder 76 includes a telescopic cylinder outer cylinder 761, a telescopic cylinder rod 762, the telescopic cylinder outer cylinder 761 is connected to the first-joint arm 71, the telescopic cylinder rod 762 is connected to the second-joint arm 72, the telescopic cylinder is telescopic to extend and retract the second-joint arm 72, the third-joint arm 73, and the fourth-joint arm 74 are connected by a linkage wire rope 79, and the linkage wire rope 79 is driven to realize multi-joint arm linkage when the second-joint arm 72 is telescopic. After the telescopic arm 7 extends out, the head of the grab bucket 78 reaches the bottom of the inspection well, the grab bucket oil cylinder rod 782 extends out of the outer cylinder 781 of the grab bucket oil cylinder, the grab bucket grab tab 784 hinged with the grab bucket adjusting rod 783 and the grab bucket oil cylinder rod 782 begins to open, then the grab bucket grab tab 784 hinged with the grab bucket adjusting rod 783 and the grab bucket oil cylinder rod 782 begins to close by retracting the grab bucket oil cylinder rod 782 in the outer cylinder 781 of the grab bucket oil cylinder, and sludge is grabbed.
Through the control system 2, the grab bucket oil cylinder rod 782 is controlled to perform an opposite process on the grab bucket oil cylinder outer cylinder 781 and the telescopic oil cylinder 76, and sludge is taken out of a well mouth.
The control system 2 controls the rotation of the rotating arm rotary drive 61, thereby driving the telescopic arm 7 to the upper part of the dump box 3.
As shown in fig. 8, by the control system 2, hydraulic oil is supplied to the control grapple oil cylinder rod 782 on the outer grapple oil cylinder tube 781 through the hydraulic reel 75, the grapple oil cylinder rod 782 extends out of the outer grapple oil cylinder tube 781, and the grapple grab tab 784 is opened for unloading. The next grabbing cycle can be entered after the completion of the grabbing cycle, and the grab bucket rotator 77 can be controlled through the control system 2 according to the bottom hole condition, so that the rotation angle of the grab bucket is realized, and the bottom hole can be grabbed cleanly.
After the operation is finished, the control system 2 carries out reverse operation to control the overturning oil cylinder 63, so that the telescopic arm 7 is converted into a horizontal state from a vertical state, and the hydraulic support leg 4 is controlled to retract.
The cantilever type pipeline dredging vehicle also comprises a sensor, wherein the sensor is arranged on the outer side of the rotary driving of the upright post and the outer side of the rotary driving of the rotary arm (not marked in the figure), and the sensor is combined with the control system 2 to realize angle limiting and protect equipment.
Although embodiments of the present invention have been shown and described, it will be appreciated by those skilled in the art that changes, modifications, substitutions and alterations can be made in these embodiments without departing from the principles and spirit of the invention, the scope of which is defined in the appended claims and their equivalents.