CN113362466B - Free type collection method for high-dimensional material - Google Patents
Free type collection method for high-dimensional material Download PDFInfo
- Publication number
- CN113362466B CN113362466B CN202110634121.1A CN202110634121A CN113362466B CN 113362466 B CN113362466 B CN 113362466B CN 202110634121 A CN202110634121 A CN 202110634121A CN 113362466 B CN113362466 B CN 113362466B
- Authority
- CN
- China
- Prior art keywords
- sampling
- light source
- dimensional
- vector
- network
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Classifications
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T17/00—Three-dimensional [3D] modelling for computer graphics
- G06T17/20—Finite element generation, e.g. wire-frame surface description, tesselation
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06N—COMPUTING ARRANGEMENTS BASED ON SPECIFIC COMPUTATIONAL MODELS
- G06N3/00—Computing arrangements based on biological models
- G06N3/02—Neural networks
- G06N3/04—Architecture, e.g. interconnection topology
- G06N3/045—Combinations of networks
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06N—COMPUTING ARRANGEMENTS BASED ON SPECIFIC COMPUTATIONAL MODELS
- G06N3/00—Computing arrangements based on biological models
- G06N3/02—Neural networks
- G06N3/04—Architecture, e.g. interconnection topology
- G06N3/048—Activation functions
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06N—COMPUTING ARRANGEMENTS BASED ON SPECIFIC COMPUTATIONAL MODELS
- G06N3/00—Computing arrangements based on biological models
- G06N3/02—Neural networks
- G06N3/08—Learning methods
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T15/00—Three-dimensional [3D] image rendering
- G06T15/005—General purpose rendering architectures
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T2200/00—Indexing scheme for image data processing or generation, in general
- G06T2200/08—Indexing scheme for image data processing or generation, in general involving all processing steps from image acquisition to 3D model generation
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- Theoretical Computer Science (AREA)
- General Physics & Mathematics (AREA)
- Software Systems (AREA)
- General Health & Medical Sciences (AREA)
- Computing Systems (AREA)
- Computational Linguistics (AREA)
- Data Mining & Analysis (AREA)
- Evolutionary Computation (AREA)
- Biomedical Technology (AREA)
- Molecular Biology (AREA)
- Biophysics (AREA)
- General Engineering & Computer Science (AREA)
- Artificial Intelligence (AREA)
- Mathematical Physics (AREA)
- Life Sciences & Earth Sciences (AREA)
- Health & Medical Sciences (AREA)
- Computer Graphics (AREA)
- Geometry (AREA)
- Image Analysis (AREA)
Abstract
本发明公开了一种高维材质的自由式采集方法,属于计算机图形学和计算机视觉领域,本方法提出将材质信息的学习转化为非结构化点云上的几何学习问题,将多个处于不同光照及观察方向下的采集结果组成高维点云,点云中的每个点为图像测量值和图像拍摄时物体的位姿信息组成的向量,本方法可以从无序、非规则、分布不均匀且精度受限的高维点云中有效地聚合非结构化视图的信息,恢复出高质量的材质属性。

The invention discloses a free-style acquisition method for high-dimensional materials, belonging to the fields of computer graphics and computer vision. The method proposes to transform the learning of material information into a geometric learning problem on an unstructured point cloud. The acquisition results under the illumination and observation direction form a high-dimensional point cloud, and each point in the point cloud is a vector composed of the image measurement value and the pose information of the object when the image was captured. Efficiently aggregate information from unstructured views in homogeneous and precision-limited high-dimensional point clouds to recover high-quality material properties.
Description
技术领域technical field
本发明涉及一种高维材质的自由式采集方法,属于计算机图形学和计算机视觉领域。The invention relates to a free-style acquisition method for high-dimensional materials, belonging to the fields of computer graphics and computer vision.
背景技术Background technique
真实世界物体的数字化是计算机图形学和视觉的核心问题之一。目前,数字化的真实物体可以用三维网格模型和六维的随空间变化的双向反射分布函数(SVBRDF)来表达,数字化的真实物体可以在任何视角和光照条件下逼真地再现其原貌,在文化遗产、电子商务、计算机游戏和电影制作等领域有着重要的应用。Digitization of real-world objects is one of the central problems in computer graphics and vision. At present, digitized real objects can be represented by three-dimensional mesh models and six-dimensional space-varying bidirectional reflectance distribution functions (SVBRDF). There are important applications in areas such as heritage, e-commerce, computer games and film production.
虽然高精度的几何模型可以方便地用商业移动3D扫描仪获得,但是出于以下原因,也希望开发一种轻量型设备来进行自由的外观扫描。首先,只要能够可靠地估计出摄像机的姿态,它就可以对不同大小的物体进行扫描。第二,设备的可移动性使得可以对不允许运输的对象,例如珍贵的文物执行现场扫描。此外,制造轻量级设备所需的时间短、成本低,使其能够为更广泛的受众所接受。它还提供了类似于几何扫描的用户友好的体验。While high-precision geometric models can be readily obtained with commercial mobile 3D scanners, it is also desirable to develop a lightweight device for free-looking scanning for the following reasons. First, it can scan objects of different sizes as long as the pose of the camera can be estimated reliably. Second, the mobility of the device makes it possible to perform on-site scans of objects that are not allowed to be transported, such as precious cultural relics. Furthermore, the short time and low cost required to manufacture lightweight devices make them accessible to a wider audience. It also provides a user-friendly experience similar to geometry scanning.
尽管需求激增,但有效的非平面外观扫描仍然是一个有待解决的问题。一方面,现有的大多数移动外观扫描工作都是在单点/平行光的情况下进行拍摄,这导致了四维的观察和光照方向的采样效率较低,用空间分辨率换取角度精度需要先验知识(Giljoo Nam,Joo Ho Lee,Diego Gutierrez,and Min H Kim.2018.Practical SVBRDF acquisition of3D objects with unstructured flash photography.In SIGGRAPH Asia TechnicalPapers.267.)。另一方面,固定采集系统在光照变化时依靠于固定的视图条件,目前尚不清楚如何将其扩展到移动设备,因为移动设备具有非结构化、不断变化的视图,并且由于其较小的外形尺寸而不能完全覆盖照明领域。Despite the surge in demand, effective non-planar appearance scanning remains an open problem. On the one hand, most of the existing mobile appearance scanning work is shot in the case of single point/parallel light, which leads to the low sampling efficiency of four-dimensional observation and illumination direction, and the exchange of spatial resolution for angular accuracy requires first. empirical knowledge (Giljoo Nam, Joo Ho Lee, Diego Gutierrez, and Min H Kim. 2018. Practical SVBRDF acquisition of 3D objects with unstructured flash photography. In SIGGRAPH Asia Technical Papers. 267.). On the other hand, fixed acquisition systems rely on fixed view conditions when lighting changes, and it is unclear how to extend this to mobile devices, which have unstructured, constantly changing views, and due to their small form factor size without fully covering the lighting field.
发明内容SUMMARY OF THE INVENTION
本发明的目的在于针对现有技术的不足,提供一种高维材质的自由式采集方法,本方法可以有效利用各个视图的采集条件信息,从无序、分布不均匀的采集结果中恢复出高质量的物体材质属性。The purpose of the present invention is to provide a free-form acquisition method for high-dimensional materials in view of the deficiencies of the prior art. The quality of the object material property.
本发明公开了一种高维材质的自由式采集方法,本方法的主要思想是,自由式的外观扫描可以转换为非结构化点云上的几何学习问题,点云中的每个点可以表示一个图像测量值和图像拍摄时物体的位姿信息。基于这一思想,本发明设计了一个神经网络,可在不同的非结构化视图中有效地聚合信息,重建空间独立的反射属性,并可以优化采集阶段使用的光照图案,最终得到高质量的材质采集结果。本发明不依赖于某一特定的采集设备,可采用固定物体,由人手持设备进行采集,或将物体放在转盘上旋转,固定设备采集,且不限于此两种方式。The invention discloses a free-form acquisition method for high-dimensional materials. The main idea of the method is that the free-form appearance scan can be converted into a geometric learning problem on an unstructured point cloud, and each point in the point cloud can represent An image measurement and the pose information of the object when the image was taken. Based on this idea, the present invention designs a neural network that can effectively aggregate information in different unstructured views, reconstruct spatially independent reflection properties, and can optimize the lighting patterns used in the acquisition stage, and finally obtain high-quality materials Collect results. The present invention does not depend on a specific collection device, and a fixed object can be used for collection by a person holding the device, or the object is placed on a turntable for rotation and collected by a fixed device, but is not limited to these two methods.
本方法提出将材质信息的学习转化为非结构化点云上的几何学习问题,将多个处于不同光照及观察方向下的采样结果组成高维点云,点云中的每个点为图像测量值和图像拍摄时物体的位姿信息组成的向量,本方法可以从无序、非规则、分布不均匀且精度受限的高维点云中有效地聚合非结构化视图的信息,恢复出高质量的材质属性。形式化的表示如下:This method proposes to transform the learning of material information into a geometric learning problem on an unstructured point cloud. Multiple sampling results under different illumination and viewing directions are formed into a high-dimensional point cloud, and each point in the point cloud is an image measurement. This method can effectively aggregate the information of unstructured views from high-dimensional point clouds that are disordered, irregular, unevenly distributed, and limited in accuracy, and recover high-resolution images. Quality material properties. The formal representation is as follows:
F(G(high dimensional point cloud))=mF(G(high dimensional point cloud))=m
其中,点云数据特征提取方法G不限于某一特定的网络结构,其他可以从点云中提取特征的方法也适用;非线性映射网络F不限于全连接网络;物体材质属性的表达不限于Lumitexel向量m。Among them, the point cloud data feature extraction method G is not limited to a specific network structure, and other methods that can extract features from point clouds are also applicable; the nonlinear mapping network F is not limited to a fully connected network; the expression of object material properties is not limited to Lumitexel vector m.
本方法包含两个阶段:训练阶段和采集阶段。The method consists of two phases: training phase and acquisition phase.
所述训练阶段包括以下步骤:The training phase includes the following steps:
(1)获取采集设备的参数,生成模拟实际摄像机的采集结果,作为训练数据;(1) Obtain the parameters of the acquisition device, and generate the acquisition results that simulate the actual camera as training data;
(2)使用生成的训练数据,对神经网络进行训练,神经网络的特征如下:(2) Use the generated training data to train the neural network. The characteristics of the neural network are as follows:
(2.1)神经网络的输入为k个非结构化采样下的Lumitexel向量,k为采样个数,Lumitexel的每个值描述了采样点对来自每个光源的入射光沿着某个观察方向的反射光强,Lumitexel与光源发光强度成线性关系,用线性全连接层模拟;(2.1) The input of the neural network is the Lumitexel vector under k unstructured samples, where k is the number of samples, and each value of the Lumitexel describes the reflection of the incident light from each light source along a certain viewing direction by the sampling point Light intensity, Lumitexel has a linear relationship with the luminous intensity of the light source, which is simulated by a linear fully connected layer;
(2.2)神经网络的第一层包括线性全连接层,用于模拟实际采集时所用的光照图案,将所述k个Lumitexel变换为相机采集结果,这k个采集结果分别与对应的采样点的位姿信息结合组成高维点云;(2.2) The first layer of the neural network includes a linear fully connected layer, which is used to simulate the illumination pattern used in actual acquisition, and transform the k Lumitexels into camera acquisition results, which are respectively related to the corresponding sampling points. The pose information is combined to form a high-dimensional point cloud;
(2.3)从第二层开始为特征提取网络,从所述高维点云中每个点独立地进行特征提取得到特征向量;(2.3) Starting from the second layer as a feature extraction network, independently perform feature extraction from each point in the high-dimensional point cloud to obtain a feature vector;
(2.4)特征提取网络后为最大池化层,用于聚合从k个非结构化视图中提取到的特征向量,得到全局特征向量;(2.4) The feature extraction network is followed by a maximum pooling layer, which is used to aggregate the feature vectors extracted from k unstructured views to obtain a global feature vector;
(2.5)最大池化层后为非线性映射网络,用于根据所述全局特征向量恢复出高维材质信息;(2.5) After the maximum pooling layer, a nonlinear mapping network is used to restore high-dimensional material information according to the global feature vector;
所述采集阶段包括以下步骤:The collection stage includes the following steps:
(1)材质采集:采集设备按照所述光照图案依次对目标三维物体进行照射,摄像机获得一组非结构化视图下的照片,将照片作为输入,获得采样物体带有纹理坐标的几何模型和拍摄照片时摄像机的位姿;(1) Material collection: The collection device sequentially illuminates the target 3D object according to the illumination pattern, the camera obtains a set of photos under unstructured views, and uses the photos as input to obtain the geometric model of the sampled object with texture coordinates and shoot The pose of the camera when the photo is taken;
(2)材质恢复:根据材质采集阶段拍摄照片时摄像机的位姿,得到拍摄每张照片时采样物体上每个有效纹理坐标对应顶点的位姿;根据所述采集到的照片及位姿信息,组成所述高维点云,作为神经网络的第二层特征提取网络的输入,计算得到高维材质信息。(2) Material recovery: According to the pose of the camera when the photo was taken in the material collection stage, the pose of the vertex corresponding to each valid texture coordinate on the sampled object when each photo was taken is obtained; according to the collected photos and pose information, The high-dimensional point cloud is formed as the input of the second layer feature extraction network of the neural network, and the high-dimensional material information is obtained by calculation.
进一步地,所述非结构化采样为非固定视角的自由随机采样,采样数据无序、非规则、分布不均,可采用固定物体,由人手持采集设备进行采集,或将物体放在转盘上旋转,固定设备采集。Further, the unstructured sampling is a free random sampling with a non-fixed viewing angle, and the sampling data is disordered, irregular, and unevenly distributed, and a fixed object can be used, which can be collected by a hand-held collection device, or the object can be placed on a turntable. Rotating, stationary equipment acquisition.
进一步地,在训练数据生成过程中,当光源为彩色时,需要对光源、采样物体和摄像机之间的光谱响应关系进行校正,校正方法如下:Further, in the training data generation process, when the light source is colored, it is necessary to correct the spectral response relationship between the light source, the sampled object and the camera. The correction method is as follows:
定义未知的彩色光源L的光谱分布曲线为

将任何采样点p的反射光谱分布曲线p(λ)表示为系数分别为pR,pG,pB的三个未知的基

摄像机C的光谱分布曲线表示为


在光照条件为{IR,IG,IB}={1,0,0}/{0,1,0}/{0,0,1}下,对已知反射系数为{pR,pG,pB}的色彩测试卡进行拍摄,根据摄像机采集到的测量值建立线性方程组,求解出大小为3×3×3的颜色校正矩阵δ(c1,c2,c3),表示光源、采样物体和摄像机之间的光谱响应关系。Under the illumination condition {IR, IG , IB }={1, 0, 0} /{0, 1, 0}/{0, 0, 1}, for the known reflection coefficient {p R , P G , p B } color test card for shooting, establish a linear equation system according to the measurement values collected by the camera, and solve the color correction matrix δ(c 1 , c 2 , c 3 ) with a size of 3×3×3, Represents the spectral response relationship between the light source, the sampled object, and the camera.
进一步地,训练阶段步骤(2.1)中,物体表面一采样点p在照片上的观测值B,反射函数fr和每个光源的光强的关系可以描述为:Further, in step (2.1) of the training phase, the relationship between the observation value B on the photo of a sampling point p on the surface of the object, the reflection function fr and the light intensity of each light source can be described as:

其中,I表示每个光源l的发光信息,包括:光源l的空间位置xl、光源l的法向量nl、光源l的发光强度I(l),P包含采样点p的参数信息,包括:采样点的空间位置xp、材质参数n,t,αx,αy,ρd,ρs。Ψ(xl,·)描述了光源l在不同入射方向下的光强分布,V表示xl对于xp可见性的二值函数,(·)+为两个向量的点积操作。fr(ω′i;ω′o,P)为ω′o固定时关于ω′i的二维反射函数。Among them, I represents the luminous information of each light source 1, including: the spatial position x l of the light source 1, the normal vector n l of the light source 1, the luminous intensity I(l) of the light source 1, and P contains the parameter information of the sampling point p, including : the spatial position x p of the sampling point, the material parameters n, t, α x , α y , ρ d , ρ s . Ψ(x l , ·) describes the light intensity distribution of light source l under different incident directions, V represents the binary function of the visibility of x l to x p , and (·) + is the dot product operation of two vectors. fr (ω′ i ; ω′ o , P ) is the two-dimensional reflection function about ω′ i when ω′ o is fixed.
神经网络的输入为k个非结构化采样下的Lumitexel向量记为m(l;P);The input of the neural network is the Lumitexel vector under k unstructured sampling, which is denoted as m(l;P);

上式中B为在单通道下的表示,当光源为彩色光源时,将B拓展为如下形式:In the above formula, B is the representation in a single channel. When the light source is a color light source, B is expanded to the following form:

(ω′i·np)+(-ω′i·nl)+δ(c1,c2,c3)dxl (ω′ i ·n p ) + (-ω′ i ·n l ) + δ(c 1 , c 2 , c 3 )dx l
其中,fr(ω′i;ω′o,P,c2)为fr(ω′i;ω′o,P)中
进一步地,训练阶段步骤(2.3)中,特征提取网络的公式如下:Further, in step (2.3) of the training phase, the formula of the feature extraction network is as follows:

其中,f为一维卷积函数,卷积核大小为1×1,B(I,Pj)表示第一层网络输出的结果或采集得到的测量值,


进一步地,训练阶段步骤(2.5)中,非线性映射网络形式化表达如下:Further, in step (2.5) of the training phase, the nonlinear mapping network is formally expressed as follows:


其中,fi+1为第i+1层网络的映射函数,Wi+1为第i+1层网络的参数矩阵,bi+1为第i+1层网络的偏移向量,yi+1为第i+1层网络的输出,d与s分别表示漫反射和镜面反射两个分支,输入

进一步地,所述神经网络的损失函数设计如下:Further, the loss function of the neural network is designed as follows:
(1)虚拟一个Lumitextel空间,为一个中心在采样点空间位置xp的立方体,立方体中心坐标系x轴方向为


(2)虚拟一个摄像机,观察方向为立方体z轴的正方向;(2) A virtual camera, the observation direction is the positive direction of the z-axis of the cube;
(3)对于漫反射Lumitexel,立方体分辨率为6×Nd 2,对于镜面反射Lumitexel,立方体分辨率为6×Ns 2,即每个面上均匀采样Nd 2、Ns 2个点作为光强为单位光强的虚拟点光源;(3) For the diffuse reflection Lumitexel, the cube resolution is 6×N d 2 , for the specular reflection Lumitexel, the cube resolution is 6×N s 2 , that is, N d 2 and N s 2 points are uniformly sampled on each surface as A virtual point light source whose light intensity is unit light intensity;
a.将采样点的镜面反射率ρs设为0,生成在此Lumitexel空间下的漫反射特征向量
b.将漫反射率ρd设为0,生成在此Lumitexel空间下的镜面反射特征向量
c.神经网络的输出为向量md,ms,其中md与


(4)材质特征部分的损失函数表达如下:(4) The loss function of the material feature part is expressed as follows:
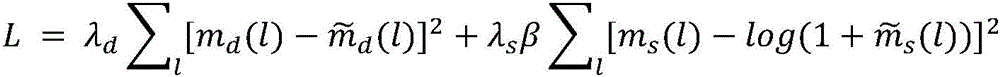
其中,λd和λs分别表示md,ms的损失权重,置信度β用来衡量镜面反射Lumitexel的损失,log作用于向量的每个维度上;置信度β的确定如下:Among them, λ d and λ s represent the loss weights of m d and m s , respectively, the confidence β is used to measure the loss of the specular Lumitexel, and the log acts on each dimension of the vector; the confidence β is determined as follows:

其中,

进一步地,所述采集阶段中,在材质采集结束后进行几何对齐,之后再进行材质恢复,几何对齐具体为:使用扫描仪扫描物体得到几何模型,将其和三维重建几何模型进行对齐后替换三维重建的几何模型。Further, in the acquisition stage, geometric alignment is performed after the material acquisition is completed, and then material recovery is performed. The geometric alignment is specifically: using a scanner to scan the object to obtain a geometric model, aligning it with the three-dimensional reconstructed geometric model, and replacing the three-dimensional model. Reconstructed geometric model.
进一步地,对于有效纹理坐标,根据所述采集到的照片及采样点的位姿信息,依次取出照片中的像素,判断像素的有效性,结合对应的顶点位姿组成高维点云;对某个有效纹理坐标确定出的采样物体表面的一点p,第j次采样对于顶点p为有效的判断标准表达如下:Further, for the effective texture coordinates, according to the collected photos and the pose information of the sampling points, the pixels in the photos are taken out in turn, the validity of the pixels is judged, and the corresponding vertex poses are combined to form a high-dimensional point cloud; A point p on the surface of the sampled object determined by valid texture coordinates, and the judgment criterion that the jth sampling is valid for vertex p is expressed as follows:
(1)顶点p位置

(2)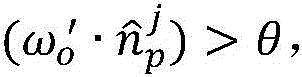

(3)照片上像素的每个通道数值处于区间[a,b],a,b为有效采样亮度的下界和上界;(3) The value of each channel of the pixel on the photo is in the interval [a, b], a, b are the lower and upper bounds of the effective sampling brightness;
当三个条件都满足时,认为第j次采样对于顶点p是有效的,将第j次采样的结果加入到高维点云中。When all three conditions are satisfied, it is considered that the jth sampling is valid for vertex p, and the result of the jth sampling is added to the high-dimensional point cloud.
进一步地,恢复材质信息后可对材质参数进行拟合,分为两步:Further, after restoring the material information, the material parameters can be fitted, which is divided into two steps:
(1)拟合局部坐标系及粗糙度:对某个有效纹理坐标确定出的采样物体表面的一点p,根据网络输出的单通道镜面反射向量,使用L-BFGS-B方法来拟合材质参数中的局部坐标系及粗糙度;(1) Fitting the local coordinate system and roughness: For a point p on the surface of the sampled object determined by a valid texture coordinate, use the L-BFGS-B method to fit the material parameters according to the single-channel specular reflection vector output by the network. The local coordinate system and roughness in ;
(2)拟合反射率:使用信赖域算法求解镜面反射率和漫反射率,求解时固定上一过程得到的局部坐标系及粗糙度,在采集所用视角下合成出观测值,使之与采集得到的观测值尽可能接近。(2) Fitting reflectance: use the trust region algorithm to solve the specular reflectance and diffuse reflectance, fix the local coordinate system and roughness obtained in the previous process, and synthesize the observation value under the viewing angle used for the acquisition, so that it is consistent with the acquisition. The resulting observations are as close as possible.
本发明的有益效果是:本发明方法提出将材质信息的学习转化为非结构化点云上的几何学习问题,将多个处于不同光照及观察方向下的采样结果组成高维点云,点云中的每个点为图像测量值和图像拍摄时物体的位姿信息组成的向量,本方法可以从无序、非规则、分布不均匀且精度受限的高维点云中有效地聚合非结构化视图的信息,恢复出高质量的材质属性。The beneficial effects of the present invention are as follows: the method of the present invention proposes to transform the learning of material information into a geometric learning problem on an unstructured point cloud, and a plurality of sampling results under different illumination and observation directions are formed into a high-dimensional point cloud. Each point in is a vector composed of the image measurement value and the pose information of the object when the image was taken. This method can effectively aggregate unstructured from high-dimensional point clouds that are disordered, irregular, unevenly distributed, and limited in accuracy. The information of the visualization view is restored to restore high-quality material properties.
附图说明Description of drawings
图1为本发明实施方式中的一种采集设备三维示意图;1 is a three-dimensional schematic diagram of a collection device in an embodiment of the present invention;
图2为本发明实施方式中的一种采集设备正视图;2 is a front view of a collection device in an embodiment of the present invention;
图3为本发明实施方式中的一种采集设备侧视图;3 is a side view of a collection device in an embodiment of the present invention;
图4为本发明实施方式中的一种采集设备与采样空间关系示意图;4 is a schematic diagram of the relationship between a collection device and a sampling space in an embodiment of the present invention;
图5为本发明实施方式的采集方法流程图;5 is a flowchart of a collection method according to an embodiment of the present invention;
图6为本发明实施方式的神经网络结构示意图;6 is a schematic diagram of a neural network structure according to an embodiment of the present invention;
图7为本发明实施方式得到的光照图案的单通道展示,使用灰度值代表发光强度;FIG. 7 is a single-channel display of a lighting pattern obtained by an embodiment of the present invention, using grayscale values to represent luminous intensity;
图8为使用本发明实施方式的系统恢复出的Lumitexel向量结果;FIG. 8 is a Lumitexel vector result recovered using the system of the embodiment of the present invention;
图9为使用本发明实施方式的系统恢复出的采样物体的材质属性结果。FIG. 9 shows the result of the material properties of the sampled object recovered by using the system of the embodiment of the present invention.
具体实施方式Detailed ways
为使本发明的目的、技术方案和优点更加清楚,下面结合附图对本发明进行详细描述。In order to make the objectives, technical solutions and advantages of the present invention clearer, the present invention will be described in detail below with reference to the accompanying drawings.
本发明提出的一种高维材质的自由式采集方法,具体实施可分为如下步骤:The method for free collection of high-dimensional materials proposed by the present invention can be specifically implemented into the following steps:
一、训练阶段:First, the training stage:
1.生成训练数据,获取采集设备的参数,包括光源到采样空间原点的距离及角度、光源的特性曲线、摄像机到采样空间原点的距离及角度、摄像机的内参和外参。利用这些参数生成模拟实际摄像机的采集结果,作为训练数据。生成训练数据时采用的渲染模型为GGX模型,生成公式如下:1. Generate training data and obtain the parameters of the acquisition device, including the distance and angle from the light source to the origin of the sampling space, the characteristic curve of the light source, the distance and angle from the camera to the origin of the sampling space, and the internal and external parameters of the camera. Use these parameters to generate acquisition results that simulate actual cameras as training data. The rendering model used when generating training data is the GGX model, and the generation formula is as follows:

其中,fr(ω′i,ω′o;P)为关于ω′i,ω′o的四维反射函数,ω′i表示世界坐标系下入射光方向,ω′o表示世界坐标系下出射光方向,ωi为局部坐标系下的入射方向,ωo为局部坐标系下的出射方向,ωh为局部坐标系下的半路向量。P包含采样点的参数信息,包括采样点的材质参数n,t,αx,αy,ρd,ρs,其中n表示世界坐标系下的法向量,t表示世界坐标系下采样点局部坐标系的x轴方向,n与t用于将入射方向和出射方向从世界坐标系转换到局部坐标系。αx,αy表示粗糙度系数,ρd表示漫反射率,ρs表示镜面反射率,ρd和ρs在单通道下都为一个标量,在彩色情况下分别为三个标量

当采集所用光源为彩色时,首先要对光源、采样物体和摄像机之间的光谱响应关系进行校正。校正方法如下:定义未知的彩色光源L的光谱分布曲线为

同样可以将任何采样点p的反射光谱分布曲线p(λ)表示为系数分别为pR,pG,pB的三个未知的基

类似地,摄像机C的光谱分布曲线可以表示为


在光照条件为{IR,IG,IB}={1,0,0}/{0,1,0}/{0,0,1}下,对已知反射系数为{pR,pG,pB}的色彩测试卡进行拍摄,根据摄像机采集到的测量值建立线性方程组,可以求解出大小为3×3×3的颜色校正矩阵δ(c1,c2,c3),表示光源、采样物体和摄像机之间的光谱响应关系。Under the illumination condition {IR, IG , IB }={1, 0, 0} /{0, 1, 0}/{0, 0, 1}, for the known reflection coefficient {p R , p G , p B } color test card for shooting, establish a linear equation system according to the measurement values collected by the camera, and solve the color correction matrix δ(c 1 , c 2 , c 3 ) with a size of 3×3×3 , which represents the spectral response relationship between the light source, the sampled object, and the camera.
2.使用生成的训练数据,对图4所示神经网络进行训练。神经网络的特征如下:2. Using the generated training data, train the neural network shown in Figure 4. The characteristics of the neural network are as follows:
(1)物体表面一采样点p在照片上的观测值B,反射函数fr和每个光源的光强的关系可以描述为:(1) The observation value B on the photo of a sampling point p on the surface of the object, the relationship between the reflection function fr and the light intensity of each light source can be described as:

其中,I表示每个光源l的发光信息,包括:光源l的空间位置xl、光源l的法向量nl、光源l的发光强度I(l),P包含采样点p的参数信息,包括:采样点的空间位置xp、材质参数n,t,αx,αy,ρd,ρs。Ψ(xl,·)描述了光源l在不同入射方向下的光强分布,V表示xl对于xp可见性的二值函数,(·)+为两个向量的点积操作,负值会被截断为0。fr(ω′i;ω′o,P)为ω′o固定时关于ω′i的二维反射函数。Among them, I represents the luminous information of each light source 1, including: the spatial position x l of the light source 1, the normal vector n l of the light source 1, the luminous intensity I(l) of the light source 1, and P contains the parameter information of the sampling point p, including : the spatial position x p of the sampling point, the material parameters n, t, α x , α y , ρ d , ρ s . Ψ(x l , ) describes the light intensity distribution of light source l under different incident directions, V represents the binary function of the visibility of x l to x p , ( ) + is the dot product operation of two vectors, negative values will be truncated to 0. fr (ω′ i ; ω′ o , P ) is the two-dimensional reflection function about ω′ i when ω′ o is fixed.
神经网络的输入为k个无序、非规则采样下的Lumitexel,k为采样个数,Lumitexel为一个向量,记为m(l;P),其中的每个值描述了采样点对来自每个光源的入射光沿着某个观察方向的反射光强;The input of the neural network is the Lumitexel under k disordered and irregular sampling, k is the number of samples, and the Lumitexel is a vector, denoted as m(l; P), where each value describes the sampling point pair from each The reflected light intensity of the incident light of the light source along a certain viewing direction;

上式中B为在单通道下的表示,当光源为彩色光源时,将B拓展为如下形式:In the above formula, B is the representation in a single channel. When the light source is a color light source, B is expanded to the following form:

其中,fr(ω′i;ω′o,P,c2)为fr(ω′i;ω′o,P)公式中
(2)神经网络的第一层包括线性全连接层,线性全连接层的参数矩阵通过以下公式训练得到:(2) The first layer of the neural network includes a linear fully connected layer, and the parameter matrix of the linear fully connected layer is trained by the following formula:
Wl=fW(Wraw)W l = f W (W raw )
其中,Wraw为待训练参数;Wl为光照矩阵,对于单通道光源,大小为1×N,对于彩色光源,大小为3×N,N为Lumitexel的向量长度;fW为一个映射,用于对Wraw进行变换,使得生成的光照矩阵能够对应到光源可能的发光强度,本实例映射fW选用Sigmoid函数,将第一层网络的光照矩阵Wl的初始化取值限制在(0,1),但fW不限于Sigmoid函数。Among them, W raw is the parameter to be trained; W l is the illumination matrix, for a single-channel light source, the size is 1 × N, for a color light source, the size is 3 × N, N is the vector length of Lumitexel; f W is a mapping, with In order to transform W raw so that the generated illumination matrix can correspond to the possible luminous intensity of the light source, the Sigmoid function is selected for the mapping f W in this example, and the initialization value of the illumination matrix W l of the first layer network is limited to (0, 1 ), but f W is not limited to the Sigmoid function.
将Wl作为光源发光强度,按照上述(1)所述关系,计算得到k个采样观测值B(I,P1),B(I,P2)...B(I,Pk)。Taking W l as the luminous intensity of the light source, according to the relationship described in the above (1), k sampling observation values B(I, P 1 ), B(I, P 2 )...B(I, P k ) are obtained by calculation.
(3)从第二层开始为特征提取网络,k个采样独立地进行特征提取得到特征向量,公式如下:(3) Starting from the second layer as a feature extraction network, k samples independently perform feature extraction to obtain feature vectors. The formula is as follows:

其中,f为一维卷积函数,卷积核大小为1×1,


(4)特征提取网络后为最大池化层。最大池化操作公式如下:(4) The feature extraction network is followed by a maximum pooling layer. The maximum pooling operation formula is as follows:
Vfeature=max(Vfeature(1),Vfeature(2),...,Vfeature(k))V feature = max(V feature (1), V feature (2), ..., V feature (k))
其中,最大池化操作在Vfeature(1),Vfeature(2),...,Vfeature(k)的每个维度上进行。Among them, the max pooling operation is performed on each dimension of V feature (1), V feature (2), ..., V feature (k).
(5)最大池化层后为非线性映射网络;(5) After the maximum pooling layer is a nonlinear mapping network;


其中,fi+1为第i+1层网络的映射函数,Wi+1为第i+1层网络的参数矩阵,bi+1为第i+1层网络的偏移向量,yi+1为第i+1层网络的输出,d与s分别表示漫反射和镜面反射两个分支,输入

(6)神经网络的损失函数如下:(6) The loss function of the neural network is as follows:
(6.1)虚拟一个Lumitextel空间,为一个中心在采样点空间位置xp的立方体,立方体中心坐标系x轴方向为

(6.2)虚拟一个摄像机,观察方向为立方体z轴的正方向;(6.2) A virtual camera, the observation direction is the positive direction of the z-axis of the cube;
(6.3)对于漫反射Lumitexel,立方体分辨率为6×Nd 2,对于镜面反射Lumitexel,立方体分辨率为6×Ns 2,即每个面上均匀采样Nd 2、Ns 2个点作为光强为单位光强的虚拟点光源,本实施例中取Nd=8,Ns=32;(6.3) For the diffuse reflection Lumitexel, the cube resolution is 6×N d 2 , for the specular reflection Lumitexel, the cube resolution is 6×N s 2 , that is, N d 2 and N s 2 points are uniformly sampled on each surface as A virtual point light source whose light intensity is unit light intensity, in this embodiment, N d =8, N s =32;
a.将采样点的镜面反射率ρs设为0,生成在此Lumitexel空间下的漫反射特征向量
b.将漫反射率ρd设为0,生成在此Lumitexel空间下的镜面反射特征向量
c.神经网络的输出为向量md,ms,其中md与


(6.4)材质特征部分的损失函数表达如下:(6.4) The loss function of the material feature part is expressed as follows:

其中,λd和λs分别表示md,ms的损失权重,置信度β用来衡量镜面反射Lumitexel的损失,log作用于向量的每个维度上;Among them, λ d and λ s represent the loss weight of m d and m s , respectively, the confidence β is used to measure the loss of the specular Lumitexel, and the log acts on each dimension of the vector;
置信度β的确定如下:The confidence level β is determined as follows:

其中,

3.训练结束后,将网络的线性全连接层的参数Wraw取出,通过公式Wl=fW(Wraw)变换后作为光照图案。3. After the training, the parameter W raw of the linear fully connected layer of the network is taken out and transformed by the formula W l =f W (W raw ) as a lighting pattern.
二、采集阶段:采集阶段又可细分为材质采集阶段、几何对齐阶段(可选的)和材质恢复阶段。2. Collection stage: The collection stage can be further subdivided into a material collection stage, a geometric alignment stage (optional) and a material recovery stage.
1.材质采集阶段1. Material collection stage
采集设备按照光照图案依次对目标三维物体进行照射,摄像机获得一组非结构化视图下的照片,将照片作为输入,使用工业界公开的三维重建工具,可以获得采样物体几何模型和拍摄照片时摄像机的位姿。The acquisition device sequentially illuminates the target 3D object according to the illumination pattern, the camera obtains a set of photos in unstructured views, and the photos are used as input. Using the 3D reconstruction tools publicly available in the industry, the geometric model of the sampled object and the camera when the photo was taken can be obtained. 's pose.
2.几何对齐阶段(可选的)2. Geometric alignment stage (optional)
(1)使用高精度扫描仪扫描物体得到几何模型;(1) Use a high-precision scanner to scan the object to obtain a geometric model;
(2)将扫描仪扫描得到的几何模型和三维重建几何模型进行对齐后替换三维重建的几何模型,对齐方法可使用领域内公开方法CPD(A.Myronenko and X.Song.2010.PointSet Registration:Coherent Point Drift.IEEE PAMI 32,12(2010),2262-2275.https://doi.org/10.1109/TPAMI.2010.46)。(2) Align the geometric model scanned by the scanner with the three-dimensional reconstructed geometric model and replace the three-dimensional reconstructed geometric model. The alignment method can use the public method CPD in the field (A.Myronenko and X.Song.2010. PointSet Registration: Coherent Point Drift. IEEE PAMI 32, 12 (2010), 2262-2275. https://doi.org/10.1109/TPAMI.2010.46).
3.材质恢复阶段:3. Material recovery stage:
(1)根据材质采集步骤拍摄照片时摄像机的位姿得到拍摄第j张照片时采样物体上每个顶点的位姿
(2)对三维重建得到的采样物体的几何模型或经对齐后的扫描仪扫所得的采样物体的几何模型,使用领域内公开工具Iso-charts,得到带有纹理坐标的几何模型;(2) For the geometric model of the sampled object obtained by the three-dimensional reconstruction or the geometric model of the sampled object obtained by scanning the aligned scanner, use the public tool Iso-charts in the field to obtain a geometric model with texture coordinates;
(3)对于有效纹理坐标,根据上述一组采集到的照片r1,r2,…,rπ及采样点的位姿信息,依次取出照片中的像素,判断像素的有效性,结合对应的顶点位姿
对某个有效纹理坐标确定出的采样物体表面的一点p,第j次采样对于点p为有效的判断标准表达如下:For a point p on the surface of the sampled object determined by a valid texture coordinate, the judgment criterion that the jth sampling is valid for the point p is expressed as follows:
1)

2)
3)照片上像素的每个通道数值处于区间[a,b],a,b为有效采样亮度的下界和上界,本实施例中取a=32,b=224;3) The value of each channel of the pixel on the photo is in the interval [a, b], a, b are the lower and upper bounds of the effective sampling brightness, and in this embodiment, a=32, b=224;
当三个条件都满足时,认为第j次采样对于点p是有效的,将第j次采样的结果加入到高维点云中;When all three conditions are met, the jth sampling is considered valid for point p, and the result of the jth sampling is added to the high-dimensional point cloud;
(4)拟合材质参数,分为两步:(4) Fitting material parameters is divided into two steps:
1)拟合局部坐标系及粗糙度1) Fitting the local coordinate system and roughness
对某个有效纹理坐标确定出的采样物体表面的一点p,根据网络输出的单通道镜面反射向量,使用L-BFGS-B方法来拟合材质参数中的局部坐标系及粗糙度,优化目标为:For a point p on the surface of the sampled object determined by a valid texture coordinate, according to the single-channel specular reflection vector output by the network, the L-BFGS-B method is used to fit the local coordinate system and roughness in the material parameters. The optimization goal is :

其中i为(6.3)中虚拟光源序号,ms(l)表示网络预测的镜面反射特征向量第l个维度上的值,ω′i表示该序号为l的虚拟光源与采样点形成的入射角,ω′o表示从采样点到(6.2)中虚拟摄像机形成的出射角,P包含该采样点的用于渲染的法向量n′、切向量t′和其他材质参数p′,因所选用模型不同而不同。如本工程所用GGX模型,则p′包括各向异性粗糙度、镜面反射率、漫反射率。上述优化目标中n′,t′,p′为可优化参数。where i is the serial number of the virtual light source in (6.3), m s (l) represents the value of the l-th dimension of the specular reflection eigenvector predicted by the network, and ω′ i represents the incident angle formed by the virtual light source with serial number l and the sampling point , ω′ o represents the outgoing angle from the sampling point to the virtual camera in (6.2), P contains the normal vector n′, tangent vector t′ and other material parameters p′ of the sampling point for rendering, because the selected model Different and different. As the GGX model used in this project, p' includes anisotropic roughness, specular reflectance, and diffuse reflectance. In the above optimization objectives, n', t', and p' are parameters that can be optimized.
2)拟合反射率2) Fitting reflectivity
该过程使用信赖域算法求解镜面反射率和漫反射率,拟合的目标为:The process uses the trust region algorithm to solve the specular reflectance and diffuse reflectance, and the goal of fitting is:

其中,
首先将漫反射率设为1,镜面反射率设为0,使用上一步得到的用于渲染的坐标系和粗糙度,渲染出第j个视角下的漫反射Lumitexel,


T=WlMjρd,s T=W l M j ρ d, s
T的大小为3×3,将其拷贝连接形成张量

以下给出一个具体的采集设备系统实例,如图1为系统实例三维展示,图2为正视图,图3为侧视图,该采集设备由1个灯板组成,上部固定有一个摄像头,用于采集图像。灯板上密集地排列了LED灯珠,共512个。灯珠由FPGA控制,可以调整发光亮度及发光时间。A specific example of the acquisition device system is given below. Figure 1 is a three-dimensional display of the system example, Figure 2 is a front view, and Figure 3 is a side view. Acquire images. There are 512 LED lamp beads densely arranged on the light board. The lamp beads are controlled by FPGA, which can adjust the light-emitting brightness and light-emitting time.
以下给出一个应用本发明方法的获取系统实例,系统总体分为如下几个模块:An example of an acquisition system applying the method of the present invention is given below, and the system is generally divided into the following modules:
准备模块:为网络训练提供数据集,该部分使用GGX模型,输入一组材质参数及k个采样点的位姿信息,摄像机位置,可得到k个反射情况组成的高维点云。网络训练部分使用Pytorch开源框架,并使用Adam优化器进行训练。网络结构如图6所示,每个矩形表示一层神经元,矩形中的数字表示该层神经元个数。最左侧层为输入层,最右侧层为输出层。层与层之间实线箭头表示全连接,虚线箭头表示卷积。Preparation module: Provide a data set for network training. This part uses the GGX model to input a set of material parameters, the pose information of k sampling points, and the camera position, and a high-dimensional point cloud composed of k reflections can be obtained. The network training part uses the Pytorch open source framework and uses the Adam optimizer for training. The network structure is shown in Figure 6. Each rectangle represents a layer of neurons, and the number in the rectangle represents the number of neurons in the layer. The leftmost layer is the input layer, and the rightmost layer is the output layer. The solid arrows between layers represent full connections, and the dashed arrows represent convolutions.
采集模块:设备如图1、2、3所示,具体构成上文已描述,本系统定义的采样空间大小及采集设备和采样空间在空间上的位置关系如图4所示。Acquisition module: The equipment is shown in Figures 1, 2, and 3. The specific structure has been described above. The size of the sampling space defined by this system and the spatial relationship between the acquisition equipment and the sampling space are shown in Figure 4.
恢复模块:用三维重建得到的采样物体的几何模型或经对齐后的扫描仪扫所得的采样物体的几何模型计算得到带有纹理坐标的几何模型,加载训练好的神经网络,对带有纹理坐标的几何模型上的每个顶点,预测材质特征向量,拟合用于渲染的坐标系和材质参数。Recovery module: Use the geometric model of the sampled object obtained by 3D reconstruction or the geometric model of the sampled object scanned by the aligned scanner to obtain the geometric model with texture coordinates, load the trained neural network, and analyze the texture coordinates. For each vertex on the geometry model, predict the material feature vector, fit the coordinate system and material parameters used for rendering.
图5为本实施例的工作流程。首先生成训练数据,随机采样得到2亿个Lumitexel,取80%作为训练集,其余作为验证集。训练网络时使用Xavier方法进行初始化参数,学习率为1e-4。光照图案为彩色,光照矩阵的大小为(3,512),矩阵的三行分表表示红、绿、蓝三通道的光照图案。训练结束后,将光照矩阵取出,变换为光照图案,每列的参数指定了该位置处,光源的发光强度,图7展示了一个网络训练得到的红、绿、蓝三通道光照图案。接下来的流程为:1.手持设备,灯板按光照图案发光,摄像机同时对物体进行拍摄,得到一组采样结果。2.对于三维重建得到的采样物体的几何模型或经对齐后的扫描仪扫所得的采样物体的几何模型,使用Isochart得到带有纹理坐标的几何模型。3.对带有纹理坐标的几何模型上的每个顶点,根据采样时的位姿及采样照片的像素值找到对应的有效的实拍数据,组成高维点云输入网络,恢复出漫反射特征向量和镜面反射特征向量。4.根据网络输出的漫反射特征向量和镜面反射特征向量,对每个顶点使用LBFGS-B方法拟合用于渲染的坐标系及粗糙度,使用信赖域算法求解镜面反射率和漫反射率。FIG. 5 is a workflow of this embodiment. First, generate training data, randomly sample 200 million Lumitexels, take 80% as the training set, and the rest as the validation set. The Xavier method is used to initialize the parameters when training the network, and the learning rate is 1e-4. The illumination pattern is color, the size of the illumination matrix is (3,512), and the three rows of the matrix represent the illumination patterns of the red, green and blue channels. After the training, the illumination matrix is taken out and transformed into an illumination pattern. The parameters of each column specify the luminous intensity of the light source at that position. Figure 7 shows the red, green, and blue three-channel illumination pattern obtained by a network training. The next process is: 1. Handheld device, the light board emits light according to the light pattern, and the camera shoots the object at the same time to obtain a set of sampling results. 2. For the geometric model of the sampled object obtained by 3D reconstruction or the geometric model of the sampled object obtained by scanning with the aligned scanner, use Isochart to obtain the geometric model with texture coordinates. 3. For each vertex on the geometric model with texture coordinates, find the corresponding valid real shot data according to the pose during sampling and the pixel value of the sampled photo, form a high-dimensional point cloud input network, and restore the diffuse reflection feature vector and specular eigenvectors. 4. According to the diffuse and specular eigenvectors output by the network, use the LBFGS-B method for each vertex to fit the coordinate system and roughness used for rendering, and use the trust region algorithm to solve the specular reflectance and diffuse reflectance.
图8展示了两个使用上述系统恢复出验证集中的Lumitexel向量,左侧一列为
图9展示了使用上述系统对采样物体进行材质外观扫描恢复出的材质属性结果,第一行分别表示采样物体

以上所述,仅为较佳实施样例,本发明并不局限于上述实施方式,只要以相同手段达到本发明的技术效果,都应属于本发明的保护范围。在本发明的保护范围内,其技术方案和/或实施方式可以有各种不同的修改和变化。The above descriptions are only examples of preferred embodiments, and the present invention is not limited to the above-mentioned embodiments. As long as the technical effect of the present invention is achieved by the same means, it should belong to the protection scope of the present invention. Within the protection scope of the present invention, various modifications and changes may be made to its technical solutions and/or implementations.
Claims (10)


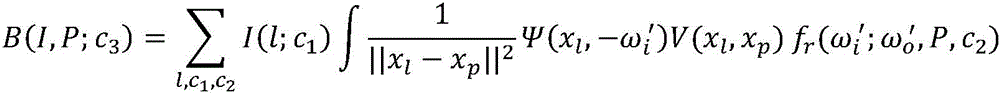


Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110634121.1A CN113362466B (en) | 2021-06-07 | 2021-06-07 | Free type collection method for high-dimensional material |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110634121.1A CN113362466B (en) | 2021-06-07 | 2021-06-07 | Free type collection method for high-dimensional material |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN113362466A CN113362466A (en) | 2021-09-07 |
| CN113362466B true CN113362466B (en) | 2022-06-21 |
Family
ID=77533025
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202110634121.1A Active CN113362466B (en) | 2021-06-07 | 2021-06-07 | Free type collection method for high-dimensional material |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN113362466B (en) |
Families Citing this family (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN116363187B (en) * | 2023-04-14 | 2025-10-31 | 浙江大学 | Structured light method for high-precision collection of geometry and materials under single visual angle |
| CN116645497B (en) * | 2023-06-29 | 2025-08-19 | 浙江大学 | Method and system for acquiring plane material database based on neural network |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN105844695A (en) * | 2016-03-18 | 2016-08-10 | 山东大学 | Illumination modeling method based on real material measurement data |
| CN107452060A (en) * | 2017-06-27 | 2017-12-08 | 西安电子科技大学 | Full angle automatic data collection generates virtual data diversity method |
| CN109272117A (en) * | 2018-10-10 | 2019-01-25 | 南昌航空大学 | A kind of bloom elimination new method based on deep learning |
| CN110570503A (en) * | 2019-09-03 | 2019-12-13 | 浙江大学 | Method for acquiring normal vector, geometry and material of three-dimensional object based on neural network |
Family Cites Families (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US11182612B2 (en) * | 2019-10-28 | 2021-11-23 | The Chinese University Of Hong Kong | Systems and methods for place recognition based on 3D point cloud |
| US11295517B2 (en) * | 2019-11-15 | 2022-04-05 | Waymo Llc | Generating realistic point clouds |
-
2021
- 2021-06-07 CN CN202110634121.1A patent/CN113362466B/en active Active
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN105844695A (en) * | 2016-03-18 | 2016-08-10 | 山东大学 | Illumination modeling method based on real material measurement data |
| CN107452060A (en) * | 2017-06-27 | 2017-12-08 | 西安电子科技大学 | Full angle automatic data collection generates virtual data diversity method |
| CN109272117A (en) * | 2018-10-10 | 2019-01-25 | 南昌航空大学 | A kind of bloom elimination new method based on deep learning |
| CN110570503A (en) * | 2019-09-03 | 2019-12-13 | 浙江大学 | Method for acquiring normal vector, geometry and material of three-dimensional object based on neural network |
Non-Patent Citations (2)
| Title |
|---|
| 不透明材质反射属性采集及建模技术综述;胡勇等;《计算机辅助设计与图形学学报》;20090915(第09期);第1193-1202页 * |
| 支持向量学习机在点云去噪中的应用;张琴等;《计算机技术与发展》;20110610(第06期);第85-88,94页 * |
Also Published As
| Publication number | Publication date |
|---|---|
| CN113362466A (en) | 2021-09-07 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN106228507B (en) | A kind of depth image processing method based on light field | |
| EP3664039B1 (en) | Method for acquiring three-dimensional object by using artificial lighting photograph and device thereof | |
| EP3382645B1 (en) | Method for generation of a 3d model based on structure from motion and photometric stereo of 2d sparse images | |
| JP2023511747A (en) | Systems and methods for synthesizing data for training statistical models with different imaging modalities, including polarization imaging | |
| CN105844695B (en) | Illumination modeling method based on real material measurement data | |
| Kniaz et al. | Thermalnet: a deep convolutional network for synthetic thermal image generation | |
| CN112330813A (en) | A reconstruction method of 3D human model under clothing based on monocular depth camera | |
| CN112070889B (en) | A three-dimensional reconstruction method, device, system, electronic device and storage medium | |
| CN108520537A (en) | A Binocular Depth Acquisition Method Based on Photometric Parallax | |
| CN108053435A (en) | Dynamic realtime three-dimensional rebuilding method and system based on handheld mobile device | |
| CN107657656B (en) | Homonymy point matching and three-dimensional reconstruction method, system and luminosity stereo camera terminal | |
| CN110728671A (en) | Vision-Based Dense Reconstruction Methods for Textureless Scenes | |
| US12482179B2 (en) | Freestyle acquisition method for high-dimensional material | |
| GB2603951A (en) | Image Processing | |
| Ciortan et al. | A practical reflectance transformation imaging pipeline for surface characterization in cultural heritage | |
| CN113362466A (en) | Free type collection method for high-dimensional material | |
| CN108447096B (en) | Information fusion method of kinect depth camera and thermal infrared camera | |
| CN111951333A (en) | Method, system, terminal and storage medium for automatic generation of six-dimensional pose data set | |
| Ono et al. | Practical BRDF reconstruction using reliable geometric regions from multi-view stereo | |
| CN110378995A (en) | A method of three-dimensional space modeling is carried out using projection feature | |
| Lee et al. | Estimation of 3D Faces and Illumination from Single Photographs Using a Bilineaur Illumination Model | |
| Mansouri et al. | Toward a 3D multispectral scanner: An application to multimedia | |
| CN114119995B (en) | An air-ground image matching method based on object aspects | |
| CN119515945B (en) | High-precision three-dimensional surface reconstruction method and device based on polarization information enhancement | |
| CN117876562A (en) | An Optimized Approach for Texture Mapping of Non-Lambertian Surfaces Based on Consumer-Grade RGB-D Sensors |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |