Disclosure of Invention
In view of the above-mentioned drawbacks and deficiencies of the prior art, it is desirable to provide an intelligent numerical control machine tool.
The application provides an intelligent numerical control machine tool, including being used for bearing the seat of carrying of treating the machined part, carry the seat and include:
the loading seat comprises a loading seat body, wherein a mounting cavity is formed in the loading seat body, at least one first mounting groove and at least one second mounting groove which are communicated with the mounting cavity are concavely arranged at the top of the loading seat body, and the at least one first mounting groove and the at least one second mounting groove are respectively positioned on two sides of the middle part of the loading seat body;
the chip removal piece is arranged in the mounting cavity and forms a chip collection space with the bottom wall of the mounting cavity, the chip removal piece comprises a first chip removal plate and a second chip removal plate which are arranged at intervals, the first chip removal plate is provided with a first covering position and a first chip removal position, the first chip removal position is positioned below the first covering position, when the first covering position is adopted, the first chip removal plate covers the top wall of the mounting cavity to seal the bottom of at least one first mounting groove, and when the first chip removal position is adopted, an interval space is formed between the first chip removal plate and the top wall of the mounting cavity; the second chip removal board covers in the roof of installation cavity in order to the bottom of shutoff at least one second mounting groove, the movably setting of second chip removal board is in order to move to the interval space, wherein the second chip removal board exposes the bottom of at least one first mounting groove when moving to the interval space so that the piece in at least one second mounting groove falls to the collection bits space, and the bottom surface of second chip removal board and the top surface sliding contact of first chip removal board so that to scrape off the piece that piles up to on the first chip removal board to the collection bits space and the top surface of second chip removal board and the roof sliding contact of installation cavity so that to scrape off the piece that piles up to the second chip removal board to the collection bits space.
Further, when the first chip removal position, a chip removal gap is formed between the side wall of the first chip removal plate and the side wall of the mounting cavity, the chip removal gap is located on one side, away from the second chip removal plate, of the first chip removal plate, and the size of the chip removal gap is adjustably arranged.
Furthermore, two first guide grooves are formed in the side wall of the installation cavity, the two first guide grooves are located on two sides of the first chip removal plate, two moving parts are arranged on two sides of the first chip removal plate, the moving parts are movably arranged relative to the first chip removal plate along the direction close to or far away from the chip removal gap, the two moving parts are respectively provided with a first guide protrusion, the two first guide protrusions and the two first guide grooves are arranged in a one-to-one correspondence mode, and the correspondingly arranged first guide protrusions are in guide fit with the first guide grooves;
each elastic piece is connected between each first guide protrusion and the first chip removal plate and used for providing elastic force towards the chip removal gap direction for the first guide protrusions.
Further, the chip discharging device comprises a first driving device and a second driving device, wherein the first driving device and the second driving device are located in the installation cavity, the first driving device drives the first chip discharging plate to be movably arranged so as to switch between the first covering position and the first chip discharging position, and the second driving device drives the second chip discharging plate to move.
Further, the first driving device and the second driving device are both air cylinders or screw rod transmission devices.
Furthermore, one end of the bottom surface of the second chip removal plate, which is close to the first chip removal plate, is provided with a flexible scraping piece.
Further, the scraper element is detachably arranged.
Furthermore, the diapire of installation cavity is equipped with the play bits mouth, and intelligent numerical control machine tool still includes dust extraction, and dust extraction's dust absorption mouth links to each other with the play bits mouth.
Furthermore, the first mounting groove comprises a first chip inlet and a first bottom wall arranged opposite to the first chip inlet, the first bottom wall is provided with a first opening part for communicating the first mounting groove with the mounting cavity, the first bottom wall comprises two first side edges arranged along the width direction of the first mounting groove, and a distance is reserved between the first opening part and the two first side edges;
the second mounting groove includes that the second goes into the bits mouth and goes into the second diapire that the bits mouth set up relatively with the second, and the second diapire is equipped with the second opening for second mounting groove and installation cavity intercommunication, and the second diapire includes two second sides that set up along second mounting groove width direction, all has the interval between second opening and the two second sides.
According to the intelligent numerical control machine tool provided by the application, the chip removal piece is arranged in the mounting cavity of the carrier body, the chip collection space is formed between the chip removal piece and the bottom wall of the mounting cavity, the first chip removal plate in the chip removal piece can remove chips from the first mounting groove on the carrier body, the second chip removal plate in the chip removal piece can remove chips accumulated on the first chip removal plate while removing chips from the second mounting groove on the carrier body, and the top wall of the mounting cavity can also be used for removing chips of the second chip removal plate, so that the numerical control machine tool can automatically remove chips without manual chip removal operation by workers, the labor intensity of the workers is reduced, the chip removal operation can be carried out in the working time of the intelligent numerical control machine tool, the stop time of the intelligent numerical control machine tool is not limited, and the working efficiency of the intelligent numerical control machine tool is improved, in addition, the thinning and the structure simplification of the carrier body can be facilitated while the chip removal efficiency and the chip removal effect are improved.
Detailed Description
The present application will be described in further detail with reference to the following drawings and examples. It is to be understood that the specific embodiments described herein are merely illustrative of the relevant invention and not restrictive of the invention. It should be noted that, for convenience of description, only the portions related to the present invention are shown in the drawings.
It should be noted that the embodiments and features of the embodiments in the present application may be combined with each other without conflict. The present application will be described in detail below with reference to the embodiments with reference to the attached drawings.
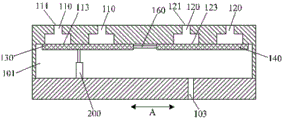
Referring to fig. 1-5, an embodiment of the present application provides an intelligent numerical control machine tool, including a carriage for carrying a workpiece to be machined, the carriage including:
the carrier seat comprises a carrier seat body 100, wherein a mounting cavity 101 is formed in the carrier seat body 100, at least one first mounting groove 110 and at least one second mounting groove 120 which are communicated with the mounting cavity 101 are concavely arranged at the top of the carrier seat body 100, the at least one first mounting groove 110 and the at least one second mounting groove 120 are respectively positioned at two sides of the middle part of the carrier seat body 100, and the at least one first mounting groove 110 and the at least one second mounting groove 120 are respectively positioned at two sides of the middle part of the carrier seat body 100;
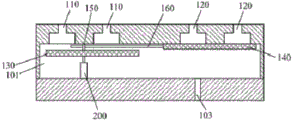
the chip removal piece is arranged in the mounting cavity 101 and forms a chip collection space with the bottom wall of the mounting cavity 101, the chip removal piece comprises a first chip removal plate 130 and a second chip removal plate 140 which are arranged at intervals, the first chip removal plate 130 is provided with a first covering position and a first chip removal position, the first chip removal position is positioned below the first covering position, when the first covering position is adopted, the first chip removal plate 130 covers the top wall of the mounting cavity 101 to seal the bottom of at least one first mounting groove 110, and when the first chip removal position is adopted, an interval space is formed between the first chip removal plate 130 and the top wall of the mounting cavity 101; the second chip removal plate 140 covers the top wall of the mounting cavity 101 to close off the bottom of the at least one second mounting groove 120, the second chip removal plate 140 is movably disposed to move to the spacing space, wherein the second chip removal plate 140 exposes the bottom of the at least one first mounting groove 110 when moving to the spacing space so that the chips in the at least one second mounting groove 120 fall into the chip collecting space, and the bottom surface of the second chip removal plate 140 is in sliding contact with the top surface of the first chip removal plate 130 to scrape the chips accumulated on the first chip removal plate 130 to the chip collecting space, and the top surface of the second chip removal plate 140 is in sliding contact with the top wall of the mounting cavity 101 to scrape the chips accumulated on the second chip removal plate 140 to the chip collecting space.
In the present embodiment, the carrier includes a carrier body 100 and a chip removal component, and the carrier body 100 carries the component to be processed. The mounting cavity 101 is formed in the carrier body 100, at least one first mounting groove 110 and at least one second mounting groove 120 are concavely arranged on the top of the carrier body 100, and the at least one first mounting groove 110 and the at least one second mounting groove 120 are respectively located on two sides of the middle of the carrier body 100 and are communicated with the mounting cavity 101. The mounting groove is used for fixing a workpiece to be machined.
Install the chip removal piece in the installation cavity 101, be formed with the collection bits space between the diapire of chip removal piece and installation cavity 101, collection bits space is used for depositing the piece that waits to treat that the machined part produces when adding man-hour. The chip discharging elements specifically include a first chip discharging plate 130 and a second chip discharging plate 140 which are arranged at intervals, the first chip discharging element is located below the at least one first mounting groove 110, and the second chip discharging element is located below the at least one second mounting groove 120. The first chip discharge plate 130 has a first cover position and a first chip discharge position, and the first chip discharge position is located below the first cover position, wherein the first chip discharge plate 130 is movably disposed in the height direction of the carriage body 100 to switch between the first cover position and the first chip discharge position. When the first dust discharging plate 130 is in the first covering position, the first dust discharging plate 130 covers the top wall of the mounting cavity 101 to close the bottom of the at least one first mounting groove 110, and at the moment, the bottom of the first mounting groove 110 is in a closed state, so that the debris can be stored in the first mounting groove 110. When the first chip removal plate 130 is at the first chip removal position, a spacing space is formed between the first chip removal plate 130 and the top wall of the mounting cavity 101, and at this time, the chips in the first mounting groove 110 can fall to the top surface of the first chip removal plate 130. The second chip ejection plate 140 has a second cover position and a second chip ejection position, and the second chip ejection plate 140 is movably disposed to switch between the second cover position and the second chip ejection position. When the second chip removal plate 140 is in the second covering position, the second chip removal plate 140 covers the top wall of the mounting cavity 101 to close the bottom of the at least one second mounting groove 120, and at this time, the bottom of the second mounting groove 120 is in a closed state, so that the debris can be stored in the second mounting groove 120. When the second chip ejection plate 140 is in the second chip ejection position, the second chip ejection plate 140 is positioned above the spacing space. During the second chip removal plate 140 moves from the second covering position to the second chip removal position, the second chip removal plate 140 may be separated from the bottom of the second mounting groove 120 so that the chips in the second mounting groove 120 fall to the chip collecting space, and the bottom surface of the second chip removal plate 140 is in sliding contact with the top surface of the first chip removal plate 130 so as to scrape the chips stacked on the first chip removal plate 130 to the chip collecting space, and the top surface of the second chip removal plate 140 is in sliding contact with the top wall of the mounting cavity 101 so as to scrape the chips stacked on the second chip removal plate 140 to the chip collecting space, so that the chips in the mounting groove are discharged to the chip collecting space. After the chips in the first and second mounting grooves 110 and 120 are discharged, the second chip discharge plate 140 is moved to the second covering position and then the first chip discharge plate 130 is moved to the first covering position to re-close the first and second mounting grooves 110 and 120.
The intelligent numerical control machine that this embodiment provided can carry out automatic chip removal with piling up the piece to the mounting groove, need not the staff and carries out artifical chip removal operation, reduces staff's intensity of labour, can also make the chip removal operation go on at intelligent numerical control machine's operating time simultaneously, need not to be restricted to intelligent numerical control machine's down time, has improved intelligent numerical control machine's work efficiency.
In addition, because during the period of non-chip removal, the bottom of the mounting groove is in a blocked state, the situation that workpieces or tools fall into a chip collecting space can be avoided, and the humanized design of the machine tool is further improved.
During the movement of the second chip removal plate 140 from the second covering position to the second chip removal position, the top surface of the second chip removal plate 140 slides on the top wall of the mounting cavity 101 to scrape off the residual chips on the top surface of the second chip removal plate 140, so that the chip removal efficiency and the chip removal effect can be improved without arranging a special scraping device, and the carrier body 100 can be thinned and simplified in structure.
Based on the structure shown in fig. 1, the first mounting groove 110 and the second mounting groove 120 are located on the left and right sides of the middle portion of the carrier body 100, at this time, the moving direction of the first chip discharging plate 130 is the inside-outside direction, and the moving direction of the second chip discharging plate 140 is the left and right direction. Of course, in other embodiments, the first and second mounting grooves 110 and 120 may also be located at the upper and lower sides of the middle portion of the carrier body 100, the moving direction of the first chip discharging plate 130 is the inside-outside direction, and the moving direction of the second chip discharging plate 140 is the up-down direction.
In some embodiments of the present application, in the first chip removal position, a chip removal gap is formed between the first chip removal plate 130 and the side wall of the mounting cavity 101, and the chip removal gap is located on a side of the first chip removal plate 130 away from the second chip removal plate 140, wherein the size of the chip removal gap is adjustably set.
In the present embodiment, when the first chip-removing plate 130 is in the first chip-removing position, a chip-removing gap is formed between the side of the first chip-removing plate 130 away from the second chip-removing plate 140 and the side wall of the mounting cavity 101. The size of chip removal clearance is set up adjustably, so can satisfy the chip removal clearance of expanding when the piece is more in order to improve the chip removal ability.
Wherein, the both ends of first chip removal board 130 all are equipped with and keep off bits portion, form clastic chip removal passageway between two fender bits portions, chip removal passageway and chip removal clearance intercommunication.
The first chip removal plate 130 and the second chip removal plate 140 may be rectangular, but not limited to rectangular, which is not limited in the present application.
In some embodiments of the present application, the side wall of the mounting cavity 101 is provided with two first guide grooves 150, the two first guide grooves 150 are located on two sides of the first chip discharging plate 130, two moving members 170 are located on two sides of the first chip discharging plate 130, the moving members 170 are movably disposed relative to the first chip discharging plate 130 along a direction close to or away from the chip discharging gap, each of the two moving members 170 is provided with a first guide protrusion 172, the two first guide protrusions 172 are disposed in one-to-one correspondence with the two first guide grooves 150, and the correspondingly disposed first guide protrusions 172 are in guiding fit with the first guide grooves 150;
an elastic member 180 is connected between each first guide protrusion 172 and the first chip discharge plate 130, and the elastic member 180 is used for providing an elastic force to the first guide protrusion 172 in a direction toward the chip discharge gap.
In this embodiment, the side wall of the mounting cavity 101 is provided with two first guide grooves 150, the first guide grooves 150 extend along the height direction of the carriage body 100, and the two first guide grooves 150 are located at two sides of the first dust discharging plate 130. Two moving pieces 170 are arranged on two sides of the first chip removal plate 130, the two moving pieces 170 are respectively provided with a first guide protrusion 172, and the corresponding first guide protrusion 172 and the first guide groove 150 are matched in a guide manner, so that the first chip removal plate 130 is arranged in a sliding manner relative to the installation cavity 101, and the first chip removal plate 130 is switched between a first covering position and a first chip removal position.
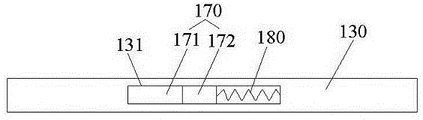
The movable member 170 is movably disposed relative to the first debris discharging plate 130 along a direction close to or away from the debris discharging gap, for example, sliding grooves 131 are disposed on both sides of the first debris discharging plate 130, and the movable member 170 is slidably disposed on the sliding grooves 131. An elastic member 180 is connected between each first guide protrusion 172 and the first chip discharge plate 130, and the elastic member 180 is used for providing an elastic force toward the chip discharge gap to the first guide protrusion 172. When the amount of chips in the chip removal gap is large, the first chip removal plate 130 is pushed to move along the direction away from the chip removal gap, so that the chip removal gap is enlarged, chip removal is promoted, and the elastic piece 180 is in an energy storage state at the moment. When the amount of debris in the debris discharge gap is small, the first debris discharge plate 130 is moved toward the debris discharge gap by the elastic member 180 to reduce the debris discharge gap.
Referring to fig. 6, the movable member 170 includes a sliding plate 171 and a first guide protrusion 172, the first guide protrusion 172 is fixed to the sliding plate 171, the sliding plate 171 is slidably disposed on the sliding groove 131, and one end of the elastic member 180 is connected to a groove wall of the sliding groove 131 and the other end is connected to the first guide protrusion 172. The elastic member 180 may be a spring, etc., and the present application does not limit this.
In this embodiment, the chip removal clearance can be in piece volume automatically regulated size, not only need not the staff operation and can also satisfy the user demand of different chip removal volume.
In some embodiments of the present application, the side wall of the mounting cavity 101 is provided with two second guide grooves 160, the second guide grooves 160 extend along the first direction, the two second guide grooves 160 are located at two sides of the second debris discharging plate 140, two sides of the second debris discharging plate 140 are provided with second guide protrusions, the two second guide protrusions are arranged in a one-to-one correspondence with the two second guide grooves 160, the second guide protrusions arranged in a corresponding manner are in guide fit with the second guide grooves 160, and the second debris discharging plate 140 can slide along the first direction relative to the mounting cavity 101 due to the arrangement. Wherein the first guide groove 150 and the second guide groove 160 are intersected.
In some embodiments of the present application, the chip cleaner further comprises a first driving device 200 and a second driving device, the first driving device 200 and the second driving device are located in the installation cavity 101, the first driving device 200 drives the first chip discharging plate 130 to be movably arranged to switch between the first covering position and the first chip discharging position, and the second driving device drives the second chip discharging plate 140 to be movably arranged along the first direction.
In the present embodiment, the first driving device 200 is drivingly connected to the first dust exhaust plate 130 to drive the first dust exhaust plate 130 to move, so that the first dust exhaust plate 130 is switched between the first covering position and the first dust exhaust position. The second driving device is in driving connection with the second chip discharge plate 140 to drive the second chip discharge plate 140 to move, so that the second chip discharge plate 140 is switched between the second covering position and the second chip discharge position.
The first driving device 200 and the second driving device are both cylinders or lead screw transmission devices, each lead screw transmission device comprises a driving motor and a lead screw transmission assembly, and the driving motors drive the lead screw transmission assemblies to drive the chip removal plates to move.
The driving end of the first driving device 200 is in movable contact with the first chip removal plate 130, so that the first chip removal plate 130 can be driven to move up and down, and the first driving device 200 cannot move along with the first chip removal plate 130 when the first chip removal plate 130 moves along the first direction.
In some embodiments of the present application, a flexible scraping element is disposed at an end of the bottom surface of the second chip removal plate 140 close to the first chip removal plate 130, so that the top surface of the first chip removal plate 130 can be scraped by the scraping element, thereby improving the chip removal effect. Wherein, the scraping piece can be a scraping brush and the like, and the application does not limit the scraping piece.
In some embodiments of the present application, the scraper member is removably arranged, such that replacement of the scraper member is facilitated. The bottom surface of the second chip removal plate 140 may be concavely provided with a containing groove, and the scraping element is clamped in the containing groove, so that the scraping element is replaceable.
In some embodiments of this application, the diapire of installation cavity 101 is equipped with out bits mouth 103, and intelligent numerical control machine tool still includes dust extraction, and dust extraction's dust absorption mouth links to each other with out bits mouth 103, so set up and to make the piece that is located collection bits space can be collected by effective clearance, improves chip removal efficiency.
In some embodiments of the present application, the first mounting groove 110 includes a first chip inlet 111 and a first bottom wall 112 disposed opposite to the first chip inlet 111, wherein the first chip inlet 111 allows chips generated during processing to enter the first mounting groove 110, the first bottom wall 112 is provided with a first opening portion 113 for communicating the first mounting groove 110 with the mounting cavity 101, the first bottom wall 112 includes two first sides disposed along a width direction of the first mounting groove 110, and a distance is provided between the first opening portion 113 and the two first sides;
the second mounting groove 120 includes a second chip inlet 121 and a second bottom wall 122 opposite to the second chip inlet 121, wherein the second chip inlet 121 is used for allowing chips generated during processing to enter the second mounting groove 120, the second bottom wall 122 is provided with a second opening 123 for communicating the second mounting groove 120 with the mounting cavity 101, the second bottom wall 122 includes two second sides arranged along the width direction of the second mounting groove 120, a distance is arranged between the second opening 123 and the two second sides, so that the first opening and the second opening can not penetrate through the carrier body 100, the overall structural strength of the carrier body 100 can be ensured, and the use of the carrier is not affected.
In the structure shown in fig. 1, the width direction of the first mounting groove 110 is the vertical direction.
It will be understood that any orientation or positional relationship indicated above with respect to the terms "central," "longitudinal," "lateral," "upper," "lower," "front," "rear," "left," "right," "vertical," "horizontal," "top," "bottom," "inner," "outer," etc., is based on the orientation or positional relationship shown in the drawings and is for convenience in describing and simplifying the invention, and does not indicate or imply that the referenced device or element must have a particular orientation, be constructed and operated in a particular orientation, and is therefore not to be considered limiting of the invention. Furthermore, the terms "first", "second" and "first" are used for descriptive purposes only and are not to be construed as indicating or implying relative importance or implicitly indicating the number of technical features indicated. Thus, a feature defined as "first" or "second" may explicitly or implicitly include one or more of that feature.
The above description is only a preferred embodiment of the application and is illustrative of the principles of the technology employed. It will be appreciated by a person skilled in the art that the scope of the invention as referred to in the present application is not limited to the embodiments with a specific combination of the above-mentioned features, but also covers other embodiments with any combination of the above-mentioned features or their equivalents without departing from the inventive concept. For example, the above features may be replaced with (but not limited to) features having similar functions disclosed in the present application.