CN112976893A - Adsorption type blackboard erasing robot - Google Patents
Adsorption type blackboard erasing robot Download PDFInfo
- Publication number
- CN112976893A CN112976893A CN202110315253.8A CN202110315253A CN112976893A CN 112976893 A CN112976893 A CN 112976893A CN 202110315253 A CN202110315253 A CN 202110315253A CN 112976893 A CN112976893 A CN 112976893A
- Authority
- CN
- China
- Prior art keywords
- sliding
- brush box
- bottom plate
- box
- brush
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images




Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B43—WRITING OR DRAWING IMPLEMENTS; BUREAU ACCESSORIES
- B43L—ARTICLES FOR WRITING OR DRAWING UPON; WRITING OR DRAWING AIDS; ACCESSORIES FOR WRITING OR DRAWING
- B43L21/00—Blackboard or slate cleaning devices
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B43—WRITING OR DRAWING IMPLEMENTS; BUREAU ACCESSORIES
- B43L—ARTICLES FOR WRITING OR DRAWING UPON; WRITING OR DRAWING AIDS; ACCESSORIES FOR WRITING OR DRAWING
- B43L12/00—Means to prevent slippage
- B43L12/02—Means to prevent slippage magnetic
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B43—WRITING OR DRAWING IMPLEMENTS; BUREAU ACCESSORIES
- B43L—ARTICLES FOR WRITING OR DRAWING UPON; WRITING OR DRAWING AIDS; ACCESSORIES FOR WRITING OR DRAWING
- B43L21/00—Blackboard or slate cleaning devices
- B43L21/02—Blackboard or slate cleaning devices with means for absorbing the chalk dust
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B62—LAND VEHICLES FOR TRAVELLING OTHERWISE THAN ON RAILS
- B62D—MOTOR VEHICLES; TRAILERS
- B62D57/00—Vehicles characterised by having other propulsion or other ground- engaging means than wheels or endless track, alone or in addition to wheels or endless track
- B62D57/02—Vehicles characterised by having other propulsion or other ground- engaging means than wheels or endless track, alone or in addition to wheels or endless track with ground-engaging propulsion means, e.g. walking members
- B62D57/024—Vehicles characterised by having other propulsion or other ground- engaging means than wheels or endless track, alone or in addition to wheels or endless track with ground-engaging propulsion means, e.g. walking members specially adapted for moving on inclined or vertical surfaces
Landscapes
- Engineering & Computer Science (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Drawing Aids And Blackboards (AREA)
Abstract
The invention relates to an adsorption type blackboard erasing robot in the technical field of robots, which comprises a shell, a magnet, a traveling mechanism and an erasing mechanism, wherein the magnet is arranged on the shell; the shell comprises a top plate and a bottom plate, and a plurality of magnets are arranged on the bottom plate at intervals; the walking mechanism comprises a first motor, walking wheels and universal wheels, the two walking wheels are rotatably connected to two opposite sides of the bottom plate, the first motor is in transmission connection with the walking wheels, and the two universal wheels are rotatably connected to two opposite ends of the bottom plate; the erasing mechanism comprises a brush box, a sliding groove, a second motor, a worm gear and a rotary table, the sliding groove is fixed on the bottom plate, the brush box is connected in the sliding groove in a sliding mode, a brush is installed on the lower end face of the brush box and extends out of the bottom plate, the second motor, the worm gear and the rotary table are connected in a transmission mode in sequence, a rotary shaft is arranged at the position, away from the circle center, of the rotary table, and the rotary shaft is connected with the brush box and drives the brush box to reciprocate along the sliding groove. The magnetic adsorption type blackboard erasing robot provided by the invention is compact in structure, convenient to operate and good in erasing effect.
Description
Technical Field
The invention relates to the technical field of robots, in particular to an adsorption type blackboard erasing robot.
Background
Chalk and blackboard eraser are still an indispensable teaching tool in present education. The chalk writing brings great progress and contribution to human beings with history progress and social development, but the traditional blackboard erasing mode brings great harm to teachers and students engaged in education, the blackboard needs to be erased manually, and a large amount of dust has great influence on the body health of users. People continuously think of and try to beautify the teaching environment, invent dustless chalk, better blackboard, utilize multimedia teaching such as projecting apparatus, but there is not better mode to replace blackboard teaching so far. Therefore, a blackboard cleaning robot or device is developed, and it is very important to ensure that teachers suck chalk dust as little as possible. Therefore, the health of teachers and students is effectively guaranteed, the time for the teachers to wipe the blackboard is saved, and valuable classroom time is brought to the students.
Through the discovery of literature retrieval, current blackboard cleaning robot mainly uses magnetism to adsorb as leading, adopts the electro-magnet to provide the adsorption affinity more, need consume the electric energy, and running gear is mostly crawler-type structure of marcing, because track and blackboard face area of contact are great, makes it turn to the resistance big, turns to the radius big, turns to the flexibility relatively poor. Or the permanent magnet is adopted for adsorption, the adsorption force of the permanent magnet cannot be adjusted, so that the movement resistance is large, the movement performance and the safety performance of the blackboard are reduced, and the blackboard cannot be suitable for various types of blackboards.
Taking an example of a blackboard erasing robot disclosed in the Chinese invention patent with the publication number of CN105730103A, the device comprises a body, a walking mechanism and an erasing mechanism which are arranged on the body, and a control system connected with the walking mechanism and the erasing mechanism; the permanent magnets are fixedly connected to the wall of the smoothbore and symmetrically distributed, and the body is adsorbed on the blackboard; the erasing mechanism adopts electromagnetic driving and removes the writing on the blackboard through vibration. Although the blackboard erasing robot is used for automatically erasing the blackboard and sucking and storing chalk dust along a specified path, the position of the permanent magnet cannot be adjusted, the magnetic force cannot be adjusted according to different ferromagnetic blackboards, the electromagnetic driving erasing mechanism and the permanent magnet mutually generate magnetic field interference, so that the two mechanisms are failed, an ideal cleaning effect cannot be achieved, and even the blackboard erasing robot falls off due to insufficient adsorption force, so that safety accidents are caused. The blackboard erasing robot has complex parts and high price.
The present invention has been made in view of this point.
Disclosure of Invention
Aiming at the defects in the prior art, the invention aims to provide an adsorption type blackboard erasing robot.
The invention provides an adsorption type blackboard erasing robot which comprises a shell, a magnet, a traveling mechanism and an erasing mechanism, wherein the magnet is arranged on the shell;
the shell comprises a top plate and a bottom plate, and a plurality of magnets are arranged on the bottom plate at intervals;
the walking mechanism comprises a first motor, walking wheels and universal wheels, the two walking wheels are rotatably connected to two opposite sides of the bottom plate, the first motor is in transmission connection with the walking wheels, the two universal wheels are rotatably connected to two opposite ends of the bottom plate, and a connecting line of the two walking wheels and a connecting line of the two universal wheels are crossed to form a cross shape;
the erasing mechanism comprises a brush box, a sliding groove, a second motor, a worm gear and a rotary table, the sliding groove is fixed on the bottom plate, the brush box is connected with the sliding groove in a sliding mode, a brush is installed on the lower end face of the brush box, the brush extends to the outside of the bottom plate, the second motor is installed on the top plate, the second motor, the worm gear and the rotary table are connected in a transmission mode in sequence, a rotating shaft is arranged at the position, away from the center of a circle, of the rotary table, and the rotating shaft is connected with the brush box and drives the brush box to follow the sliding groove in a reciprocating mode.
In some embodiments, the upper end surface of the brush box is provided with a guide groove, the axial direction of the guide groove is perpendicular to the movement direction of the brush box, and the rotating shaft extends into the guide groove and is connected with the guide groove in a sliding manner.
In some embodiments, the chute includes a first slide plate and a second slide plate, the first slide plate and the second slide plate being connected to the base plate, and the brush box being slidably sandwiched between the first slide plate and the second slide plate.
In some embodiments, the first sliding plate and the second sliding plate are provided with symmetrical sliding holes, two side surfaces of the brush box are provided with sliding columns, and the sliding columns on two sides respectively extend into the sliding holes and slide along the sliding holes.
In some embodiments, the surface of the slide hole is provided with a layer of copper sheet, and the surface of the slide column is in contact with the copper sheet.
In some embodiments, the magnet mounting rack is of a groove structure, the magnet is arranged in a groove of the magnet mounting rack, the magnet mounting rack is connected to the bottom plate, and the height between the magnet and the bottom plate is adjustable.
In some embodiments, the dust collection device further comprises a dust collection mechanism, the dust collection mechanism comprises a suction pipe and a fan, the fan is mounted on the bottom plate, one end of the suction pipe is communicated with an air suction opening of the fan, the other end of the suction pipe is communicated with the brush box, and a plurality of dust collection holes are formed in the lower end face of the brush box.
In some embodiments, a filter screen is arranged in the brush box and is arranged between the interface of the suction pipe communicated with the brush box and the dust suction hole.
In some embodiments, the brush box is a split structure, and includes a first box and a second box, the first box and the second box are connected in a drawer-type manner, and the first box and the second box are in interference fit.
In some embodiments, the erasing mechanisms are two sets, and the two sets of sliding grooves fixed on the bottom plate are parallel to each other.
Compared with the prior art, the invention has the following beneficial effects:
1. the magnetic adsorption type blackboard erasing robot provided by the invention is compact in structure, convenient to operate and good in erasing effect.
2. The sliding chute is suitable for different types of brush boxes by designing the sliding chute with a split structure, and meanwhile, the matching structure of the sliding chute and the brush boxes is optimized, and the friction resistance of the sliding chute and the brush boxes is reduced.
3. According to the invention, the magnet mounting bracket is arranged, so that the problem of adjustment of the magnetic attraction between the robot and the blackboard is effectively solved, and the robot can adapt to different types of blackboards.
4. The invention improves the dust absorption effect in the blackboard erasing process and reduces the dust pollution by arranging the dust absorption mechanism and optimizing and improving the adaptability of the brush box.
Drawings
Other features, objects and advantages of the invention will become more apparent upon reading of the detailed description of non-limiting embodiments with reference to the following drawings:
FIG. 1 is a schematic view of the overall structure of the apparatus of the present invention;
FIG. 2 is a schematic view of the internal structure of the apparatus of the present invention with the upper plate removed;
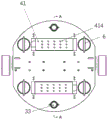
FIG. 3 is a bottom view of the apparatus of the present invention;
FIG. 4 is a cross-sectional view taken along plane A-A of FIG. 3;
FIG. 5 is a schematic diagram of an erasing apparatus of the present invention;
FIG. 6 is a schematic view of the assembly of the brush box of the apparatus of the present invention;
fig. 7 is a schematic view of the installation of a rubidium-iron-boron magnet in the device of the present invention.
Detailed Description
The present invention will be described in detail with reference to specific examples. The following examples will assist those skilled in the art in further understanding the invention, but are not intended to limit the invention in any way. It should be noted that it would be obvious to those skilled in the art that various changes and modifications can be made without departing from the spirit of the invention. All falling within the scope of the present invention.
Example 1
The invention provides an adsorption type blackboard erasing robot which comprises a shell 1, and a ferromagnetic part 2, a traveling mechanism 3 and an erasing mechanism 4 which are arranged on the shell 1. The shell 1 is of an upper shell structure and a lower shell structure and mainly comprises a top plate 11 and a bottom plate 12, the top plate 11 and the bottom plate 12 are used as substrates for mounting other components, and structures such as corresponding grooves and holes are formed in the top plate 11 and the bottom plate 12, so that the mounting and fixing of other components are facilitated. Both the top plate 11 and the bottom plate 12 may be circular plates, rectangular plates, preferably runway-type structural plates. Both side surfaces of the straight line of the top plate 11 and the bottom plate 12 of the runway type structure may provide a mounting space for the road wheels. The magnets 2 are preferably a plurality of rubidium-iron-boron magnets mounted and fixed on the base plate 12, and the plurality of magnets 2 are preferably distributed at intervals in the circumferential direction of the base plate 12. Preferably, when the bottom plate 12 is a runway-type structural plate, the magnets 2 are fixed at four corners of the bottom plate 12, and the robot can be adsorbed on the blackboard by generating magnetic attraction between the magnets 2 and the blackboard.
The traveling mechanism 3 includes a first motor 31, traveling wheels 32, and universal wheels 33. The first motor 31 provides power to drive the travelling wheels 32 to move forwards and backwards and steer, and the universal wheels 33 serve as auxiliary driven wheels to ensure the smooth running of the robot, particularly the stability during steering action. The first motor 31 is fixed on the bottom plate 12, the two traveling wheels 32 are respectively and fixedly connected to two opposite side edges of the bottom plate 12, and the first motor 31 is in transmission connection with the traveling wheels 32 and drives the traveling wheels 32 to move forwards or backwards. Preferably, two road wheels 32 are fixed to the base plate 12 at opposite ends of the transverse central axis. The transmission connection of the two traveling wheels 32 and the first motor 31 has various forms, one connection mode can be that the first motor 31 is a differential motor, and the forward movement, the backward movement and the steering of the robot are realized through the arrangement of the rotating speeds of two half shafts in transmission connection with the two traveling wheels 32; in another connection mode, the number of the first motors 31 is two, the two first motors 31 respectively and independently control one traveling wheel 32, and the purposes of advancing, retreating and steering are realized through the rotation speed setting of the two first motors 31 which independently operate. Preferably, the two universal wheels 33 are located on the vertical central axis of the bottom plate 12. At the moment, the connecting line of the two walking wheels 32 and the connecting line of the two universal wheels 33 are crossed into a cross shape.
The erasing mechanism 4 is used for erasing the writing on the blackboard, and mainly comprises a brush box 41, a chute 42, a second motor 43, a worm gear 44 and a turntable 45. The brush box 41 is a cavity structure, and preferably has a square box shape, and a brush 411 is arranged on the lower end surface of the brush box, and the brush 411 is used for contacting the blackboard and erasing the writing on the blackboard. The sliding slot 42 is fixed on the bottom plate 12, the brush box 41 is slidably mounted in the sliding slot 42, the sliding slot 42 is used for enabling the moving direction of the brush box 41 to move along the axial direction of the sliding slot 42, a hole for enabling the brush 411 to penetrate out is formed in the bottom plate 12 corresponding to the brush box 41 in the sliding slot 42, and part or all of the brush 411 is located on the outer side of the bottom plate 12. The second motor 43, the worm gear 44 and the rotating disc 45 are sequentially connected in a rotating mode, the second motor 43 is installed on the top plate 11, the worm of the worm gear 44 is connected with the second motor 42 in a rotating mode, the worm wheel of the worm gear 44 can be connected with the rotating disc 45 in a rotating mode through the rotating shaft, the rotating disc 45 is provided with a rotating shaft 451, the rotating shaft 451 is far away from the circle center position of the rotating disc 45, and the rotating shaft 451 is connected with the brush box 41 and drives the brush box 41 to reciprocate along the axis of the sliding groove 42. Preferably, the upper end surface of the brush box 41 is formed with a guide groove 412, the guide groove 412 is formed along a direction perpendicular to the movement direction of the brush box 41, the rotating shaft 451 is disposed in the guide groove 412, and the outer diameter of the rotating shaft 451 is substantially the same as the width of the guide groove 412, so that when the rotating disc 45 rotates with the worm gear 44, the rotating shaft 451 disposed in the guide groove 412 drives the brush box 41 to reciprocate along the axial direction of the sliding groove 42.
The working principle of the invention is as follows: after the magnetic adsorption type blackboard cleaning robot is placed on the blackboard, the wheel surfaces of the two walking wheels 32 and the two universal wheels 33 and the hairbrush 411 are all in contact with the surface of the blackboard, a certain distance exists between the bottom plate 12 and the surface of the blackboard, and at the moment, the robot is adsorbed on the blackboard through the magnetic adsorption force generated between the magnet 2 arranged on the bottom plate 12 and the blackboard. The first motor 31 is started to drive the travelling wheels 32 to travel forwards and backwards or turn to the area to be erased on the blackboard surface, the second motor 43 drives the worm gear 44 to rotate, the worm gear 44 drives the turntable 45 to rotate, the rotating shaft 451 which is far away from the center of the circle of the turntable 45 at a certain position pushes the brush box 41 to slide back and forth along the axial chute surface of the chute 42, and then the writing on the blackboard surface is erased through the back and forth sliding of the brush 411. The application provides a blackboard robot is wiped to magnetism absorption formula compact structure, convenient operation erases effectually.
Preferably, the erasing mechanisms 4 arranged on the bottom plate 12 are two groups, the two groups of erasing mechanisms 4 are arranged at a certain distance, and the sliding grooves 42 on the two groups of erasing mechanisms 4 are parallel to each other, so that the moving directions of the brushes are consistent, and the erasing effect can be further improved.
Example 2
This embodiment 2 forms on embodiment 1's basis, through the spout of design components of a whole that can function independently structure for the brush box of the applicable different models of spout optimizes the adaptation structure of spout and brush box simultaneously, reduces the frictional resistance of spout and brush box. Specifically, the method comprises the following steps:
the sliding groove 42 is formed by two sliding plates and comprises a first sliding plate 421 and a second sliding plate 422, the first sliding plate 421 and the second sliding plate 422 are fixed on the bottom plate 12 in parallel after being separated by a certain distance, and the brush box 41 is slidably arranged between the first sliding plate 421 and the second sliding plate 422. The brush box 41 and the first and second sliding plates 421 and 422 preferably slide the brush box 41 by the cooperation of the holes and the posts, specifically: the two side surfaces of the brush box 41 are provided with convex sliding columns 413, and the first sliding plate 421 and the second sliding plate 422 are respectively provided with sliding holes 423, and the two sliding holes are symmetrically arranged. The sliding holes 423 are preferably of a track type and are respectively arranged along the axial direction of the first sliding plate 421 and the second sliding plate 422, the sliding columns 413 at both sides respectively extend into the sliding holes 423 of the first sliding plate 421 and the second sliding plate 422, and the brush box 41 can slide by the cooperation of the sliding columns 412 and the sliding holes 423. The sliding groove 42 is formed by combining split sliding plates, so that the groove width can be adjusted according to the size of the brush box 41, and meanwhile, the split sliding groove 42 and the brush box 41 are provided with the matched sliding hole 423 and the sliding column 413, so that a certain gap is kept between the side surface of the brush box 41 and the inner surface of the sliding groove 42, and the sliding friction resistance is reduced.
Furthermore, a layer of copper sheet is arranged on the surface of the sliding hole 423, and the copper sheet is thin and can be placed on the surface of the sliding hole 423 through gluing and the like. The surface of the sliding hole 423 is provided with a layer of copper sheet, and the copper sheet is in contact with the surface of the sliding column 413, so that the friction force between the sliding column 413 and the sliding hole 423 can be effectively reduced, and meanwhile, the heat dissipation effect can be improved.
Example 3
This embodiment 3 forms on the basis of embodiment 1 or embodiment 2, through setting up the magnet installing support, has effectively solved the regulation problem of magnetic attraction between robot and the blackboard for the adaptable different kinds of blackboards of robot. Specifically, the method comprises the following steps:
Example 4
The embodiment 4 is formed on the basis of any one of the embodiments 1 to 3, and the dust absorption effect in the blackboard erasing process is improved and the dust pollution is reduced by setting the dust absorption mechanism and optimizing and improving the adaptability of the brush box. Specifically, the method comprises the following steps:
a dust suction mechanism 7 is provided in communication with the brush box 41, and the dust suction mechanism 7 includes a suction pipe 71 and a fan 72. The fan 72 is located on the bottom plate 12, and when two sets of erasing mechanisms 4 are installed on the bottom plate 12, the fan 72 is installed between the two sets of erasing mechanisms 4, specifically, between the two sets of chutes 42, so that the suction pipe 71 is conveniently communicated with the brush boxes 41 on the two sides. One end of the suction pipe 71 is communicated with the air suction opening of the fan 72, the other end is communicated with the notch formed in the brush box 41, preferably, the upper end face of the brush box 41 is provided with the notch, and the other end of the suction pipe 71 is connected to the notch on the upper end face of the brush box 41. Correspondingly, the lower end surface of the brush 411 of the brush box 41 is provided with a corresponding dust suction hole 414, and the dust suction holes 414 are uniformly distributed on the lower end surface of the brush box 41. Suction tube 71 is preferably a PE plastic bellows
When the brush 411 removes the writing on the blackboard by the reciprocating swing of the brush box 41, the suction force generated by the fan 72 sucks the air in the brush box 41 through the suction pipe 71, so that the inside of the brush box 41 is in a negative pressure state, and the dust erased at this time enters the brush box 41 through the dust suction hole 414, thereby completing the dust adsorption and collection.
Preferably, a filter screen 415 is arranged in the brush box 41, the filter screen 415 is arranged between the dust suction hole 414 and the structure for communicating the suction pipe 72 with the brush box 41, and the filter screen 415 is used for intercepting dust entering the brush box 41 from the dust suction hole 414, so as to prevent the dust from directly entering the fan 72 through the suction pipe 71 and causing damage to the fan 72.
Preferably, in order to facilitate dust cleaning, the brush box 41 is configured as a drawer-type split structure, and includes a first box 4101 and a second box 4102, the first box 4101 is inserted into the second box 4102, and the first box 4101 and the second box 4102 are preferably in interference fit, so that dust cleaning is facilitated, and meanwhile, sealing performance and structural firmness of the brush box are ensured.
In the description of the present application, it is to be understood that the terms "upper", "lower", "front", "rear", "left", "right", "vertical", "horizontal", "top", "bottom", "inner", "outer", and the like indicate orientations or positional relationships based on those shown in the drawings, and are only for convenience in describing the present application and simplifying the description, but do not indicate or imply that the referred device or element must have a specific orientation, be constructed in a specific orientation, and be operated, and thus, should not be construed as limiting the present application.
The foregoing description of specific embodiments of the present invention has been presented. It is to be understood that the present invention is not limited to the specific embodiments described above, and that various changes or modifications may be made by one skilled in the art within the scope of the appended claims without departing from the spirit of the invention. The embodiments and features of the embodiments of the present application may be combined with each other arbitrarily without conflict.
Claims (10)
1. An adsorption type blackboard erasing robot is characterized by comprising a shell (1), a magnet (2), a traveling mechanism (3) and an erasing mechanism (4);
the shell (1) comprises a top plate (11) and a bottom plate (12), and the magnets (2) are arranged on the bottom plate (12) at intervals;
the walking mechanism (3) comprises a first motor (31), walking wheels (32) and universal wheels (33), the two walking wheels (32) are rotatably connected to two opposite sides of the bottom plate (12), the first motor (31) is in transmission connection with the walking wheels (32), the two universal wheels (33) are rotatably connected to two opposite ends of the bottom plate (12), and a connecting line of the two walking wheels (32) and a connecting line of the two universal wheels (32) are crossed to form a cross shape;
erase mechanism (4) and include brush box (41), spout (42), second motor (43), worm gear (44) and carousel (45), spout (42) are fixed in on bottom plate (12), brush box (41) sliding connection in spout (42), brush (411) are installed to the lower terminal surface of brush box (41), brush (411) extend to outside bottom plate (12), second motor (43) install in on roof (11), second motor (43), worm gear (44) with carousel (45) transmission connection in proper order, the position of keeping away from its centre of a circle of carousel (45) is equipped with pivot (451), pivot (451) with brush box (41) are connected and are driven brush box (41) are followed spout (42) reciprocating motion.
2. The suction type blackboard erasing robot as claimed in claim 1, wherein a guide groove (412) is formed in the upper end surface of the brush box (41), the axial direction of the guide groove (412) is perpendicular to the moving direction of the brush box (41), and the rotating shaft (451) extends into the guide groove (412) and is connected in a sliding manner.
3. The suction blackboard erasing robot according to claim 1, wherein the chute (42) includes a first sliding plate (421) and a second sliding plate (422), the first sliding plate (421) and the second sliding plate (422) are connected to the base plate (12), and the brush box (41) is held between the first sliding plate (421) and the second sliding plate (422) and is slidable.
4. The suction type blackboard erasing robot according to claim 3, wherein the first sliding plate (421) and the second sliding plate (422) are provided with symmetrical sliding holes (423), two side surfaces of the brush box (41) are provided with sliding columns (413), and the sliding columns (413) at two sides respectively extend into the sliding holes (423) and slide along the sliding holes (423).
5. The suction blackboard erasing robot according to claim 4, wherein the surface of the sliding hole (423) is provided with a layer of copper sheet, and the surface of the sliding column (413) is in contact with the copper sheet.
6. The absorption-type blackboard erasing robot according to claim 1, further comprising a magnet mounting frame (6), wherein the magnet mounting frame (6) is of a groove structure, the magnet (2) is arranged in a groove of the magnet mounting frame (6), the magnet mounting frame (6) is connected to the bottom plate (12), and the height between the magnet (6) and the bottom plate (12) can be adjusted.
7. The absorption type blackboard erasing robot according to claim 1, further comprising a dust suction mechanism (7), wherein the dust suction mechanism (7) comprises a suction pipe (71) and a fan (72), the fan (72) is installed on the bottom plate (12), one end of the suction pipe (71) is communicated with an air suction opening of the fan (72), the other end of the suction pipe (71) is communicated with the brush box (41), and a plurality of dust suction holes (414) are formed in the lower end surface of the brush box (41).
8. The suction type blackboard erasing robot according to claim 7, wherein a filter screen (415) is arranged in the brush box (41), and the filter screen (415) is arranged between the interface of the suction pipe (71) and the brush box (41) and the dust suction hole (414).
9. The suction blackboard erasing robot according to claim 7, wherein the brush box (41) is a split structure and includes a first box (4101) and a second box (4102), the first box (4101) and the second box (4102) are inserted and connected in a drawer type manner, and the first box (4101) and the second box (4102) are in interference fit.
10. The suction type blackboard erasing robot according to any one of claims 1 to 9, wherein the erasing mechanisms (4) are provided in two sets, and the two sets of sliding grooves (42) fixed on the bottom plate (12) are parallel to each other.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110315253.8A CN112976893A (en) | 2021-03-24 | 2021-03-24 | Adsorption type blackboard erasing robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110315253.8A CN112976893A (en) | 2021-03-24 | 2021-03-24 | Adsorption type blackboard erasing robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN112976893A true CN112976893A (en) | 2021-06-18 |
Family
ID=76333442
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202110315253.8A Pending CN112976893A (en) | 2021-03-24 | 2021-03-24 | Adsorption type blackboard erasing robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN112976893A (en) |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR100735055B1 (en) * | 2006-06-08 | 2007-07-06 | 서금윤 | Electric Blackboard Eraser with Remote Control |
| CN205058998U (en) * | 2015-09-18 | 2016-03-02 | 徐景林 | Washing blackboard eraser |
| CN106864422A (en) * | 2017-02-21 | 2017-06-20 | 华中农业大学 | Intelligent domestic automobile washing machine people |
| CN108523778A (en) * | 2018-06-13 | 2018-09-14 | 山西嘉世达机器人技术有限公司 | Clean robot |
| CN108971044A (en) * | 2018-09-29 | 2018-12-11 | 钱洪武 | A kind of mobile phone dust-extraction unit |
| CN208946931U (en) * | 2018-05-25 | 2019-06-07 | 武汉科技大学 | A kind of blackboard cleaning device and blackboard |
| CN210733682U (en) * | 2019-07-10 | 2020-06-12 | 河南交通职业技术学院 | A blackboard eraser |
-
2021
- 2021-03-24 CN CN202110315253.8A patent/CN112976893A/en active Pending
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR100735055B1 (en) * | 2006-06-08 | 2007-07-06 | 서금윤 | Electric Blackboard Eraser with Remote Control |
| CN205058998U (en) * | 2015-09-18 | 2016-03-02 | 徐景林 | Washing blackboard eraser |
| CN106864422A (en) * | 2017-02-21 | 2017-06-20 | 华中农业大学 | Intelligent domestic automobile washing machine people |
| CN208946931U (en) * | 2018-05-25 | 2019-06-07 | 武汉科技大学 | A kind of blackboard cleaning device and blackboard |
| CN108523778A (en) * | 2018-06-13 | 2018-09-14 | 山西嘉世达机器人技术有限公司 | Clean robot |
| CN108971044A (en) * | 2018-09-29 | 2018-12-11 | 钱洪武 | A kind of mobile phone dust-extraction unit |
| CN210733682U (en) * | 2019-07-10 | 2020-06-12 | 河南交通职业技术学院 | A blackboard eraser |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN114532886B (en) | Cleaning device | |
| CN109434334B (en) | A cross slip table for carrying anchor clamps and realizing sharing of multi-vehicle type | |
| CN105835571B (en) | A kind of electronic blackboard with automatic blackboard eraser | |
| CN216039563U (en) | Automatic bacteria inoculation instrument | |
| CN201231625Y (en) | Blackboard capable of automatic clearing chalk dust | |
| CN204037181U (en) | A kind of Remote Control Automaticization blackboard eraser of solar energy auxiliary power supply | |
| CN105172432A (en) | Electric integrated dry wiping writing board | |
| CN204184093U (en) | A kind of automatic-cleaning backboard | |
| CN115709613A (en) | Artificial intelligence device for teaching | |
| CN103722963B (en) | Full-automatic dustless blackboard eraser | |
| CN203666210U (en) | Full-automatic dust-free blackboard eraser | |
| CN220429729U (en) | Automatic cleaning machine for magnetic writing board | |
| CN205130714U (en) | Electronic integral xerotripsis clipboard | |
| CN202293891U (en) | Controllable lifting automatic dust-removing blackboard | |
| CN216287191U (en) | Administrative management teaching device | |
| CN103612530B (en) | Flexible-belt-type automatic blackboard wiping device | |
| CN205631860U (en) | Multi -functional moving blackboard | |
| CN109910482A (en) | A kind of fully automatic blackboard scrape along tutoring system that magnetic force is controllable | |
| CN222061635U (en) | Automatic dust removal blackboard wiping device | |
| CN203381399U (en) | Automatic eraser | |
| CN209521457U (en) | Automatic dust-absorption eraser | |
| CN223643385U (en) | An automatic wall cleaning device | |
| CN221163069U (en) | Magnetic adsorption device of wall climbing robot | |
| CN215921721U (en) | Dust-absorbing electric blackboard eraser capable of automatically erasing blackboard | |
| CN107538999A (en) | A kind of automatically cleaning blackboard |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| RJ01 | Rejection of invention patent application after publication | ||
| RJ01 | Rejection of invention patent application after publication |
Application publication date: 20210618 |