CN112975252A - Clamping device for fusion welding of automobile parts - Google Patents
Clamping device for fusion welding of automobile parts Download PDFInfo
- Publication number
- CN112975252A CN112975252A CN202110287885.8A CN202110287885A CN112975252A CN 112975252 A CN112975252 A CN 112975252A CN 202110287885 A CN202110287885 A CN 202110287885A CN 112975252 A CN112975252 A CN 112975252A
- Authority
- CN
- China
- Prior art keywords
- motor
- side wall
- welded
- hinged arm
- clamping device
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Withdrawn
Links
- 238000003466 welding Methods 0.000 title claims abstract description 37
- 230000004927 fusion Effects 0.000 title claims abstract description 18
- 238000003860 storage Methods 0.000 claims abstract description 6
- 210000000080 chela (arthropods) Anatomy 0.000 claims abstract 3
- 239000007787 solid Substances 0.000 claims abstract 3
- 238000010030 laminating Methods 0.000 claims description 2
- 238000006073 displacement reaction Methods 0.000 abstract description 8
- 239000002184 metal Substances 0.000 description 6
- 229910052751 metal Inorganic materials 0.000 description 6
- 238000004804 winding Methods 0.000 description 6
- 230000033001 locomotion Effects 0.000 description 3
- 230000005540 biological transmission Effects 0.000 description 2
- 238000004519 manufacturing process Methods 0.000 description 2
- 238000000034 method Methods 0.000 description 2
- 230000004075 alteration Effects 0.000 description 1
- 230000009286 beneficial effect Effects 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 239000000428 dust Substances 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 238000005516 engineering process Methods 0.000 description 1
- 238000005286 illumination Methods 0.000 description 1
- 238000005304 joining Methods 0.000 description 1
- 150000002739 metals Chemical class 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 239000004033 plastic Substances 0.000 description 1
- 229920003023 plastic Polymers 0.000 description 1
- 238000007789 sealing Methods 0.000 description 1
- 230000000087 stabilizing effect Effects 0.000 description 1
- 238000006467 substitution reaction Methods 0.000 description 1
- 230000001360 synchronised effect Effects 0.000 description 1
- 239000012815 thermoplastic material Substances 0.000 description 1
Images




Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K37/00—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass
- B23K37/04—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass for holding or positioning work
- B23K37/0426—Fixtures for other work
- B23K37/0435—Clamps
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K37/00—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23K—SOLDERING OR UNSOLDERING; WELDING; CLADDING OR PLATING BY SOLDERING OR WELDING; CUTTING BY APPLYING HEAT LOCALLY, e.g. FLAME CUTTING; WORKING BY LASER BEAM
- B23K37/00—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass
- B23K37/04—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass for holding or positioning work
- B23K37/047—Auxiliary devices or processes, not specially adapted for a procedure covered by only one of the other main groups of this subclass for holding or positioning work moving work to adjust its position between soldering, welding or cutting steps
Landscapes
- Physics & Mathematics (AREA)
- Optics & Photonics (AREA)
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Automatic Assembly (AREA)
Abstract
The invention discloses a clamping device for fusion welding of automobile parts, which comprises a clamping mechanism, a carrying mechanism and a controller, wherein the clamping mechanism comprises a first supporting plate, a first motor, a first hinged arm, a second motor, a second hinged arm, a third motor, a third hinged arm, a fourth motor, a storage table, a servo motor, a bevel worm wheel, three bevel worms, three lead screws, three sliding blocks and three asynchronous motors, and the interior of the first supporting plate is in threaded connection with the first motor through screws; with the cooperation between servo motor, awl worm wheel, awl worm and lead screw, slider and the calliper in the solid mechanism of pincers, realize loading the demand that multiunit welding carries out the solid and displacement concatenation of pincers simultaneously, and can rely on the accurate centering demand of interval between the awl worm wheel realization part during the displacement to rely on asynchronous machine can adjust the relative angle between every part at will, thereby supplementary staff accomplishes the welding task.
Description
Technical Field
The invention relates to the technical field of automobile processing devices, in particular to a clamping device for fusion welding of automobile parts.
Background
Fusion welding is a manufacturing process and technique for joining metals or other thermoplastic materials such as plastics in a heated, high temperature or high pressure manner; in the field of automobile processing and manufacturing, particularly when welding of specially-made sheet metal parts such as a skylight brush holder or a structural flange of an automobile is involved, a plurality of sheet metal parts are generally required to be gathered to a welding seam and subjected to fusion welding, in a traditional welding mode for the parts, a worker is generally required to match the plurality of sheet metal parts in a fixing mechanism such as a bench vice or a three-jaw caliper and mutually match the sheet metal parts, and then the welded parts are processed by depending on experience, the fixing angle of the welded parts cannot be adjusted due to the fixing mode, the matching angle of the welding seam of the sheet metal parts can generate different matching angles (most common 20 degrees, 30 degrees, 35 degrees, 75 degrees and the like) due to different parts, the worker is required to additionally install auxiliary workpieces such as specially-made backing plates and match the welding work, and the fixing effect is not ideal, and is not only the working.
Therefore, a clamping device for fusion welding of automobile parts is provided.
Disclosure of Invention
The invention aims to provide a clamping device for fusion welding of automobile parts, which solves the problems in the background technology.
In order to achieve the purpose, the invention provides the following technical scheme: a clamping device for fusion welding of automobile parts comprises a clamping mechanism, a carrying mechanism and a controller, wherein the clamping mechanism comprises a first supporting plate, a first motor, a first hinged arm, a second motor, a second hinged arm, a third motor, a third hinged arm, a fourth motor, a storage table, a servo motor, a bevel worm gear, three bevel worms, three lead screws, three sliders and three asynchronous motors, the first supporting plate is connected with the first motor through screw threads inside, the first supporting plate is welded with the first hinged arm on the upper surface, the first hinged arm is connected with the second motor through screw threads on the front surface, the second motor is welded with the second hinged arm on the inner side wall, the second hinged arm is connected with the third motor through screw threads on the inner side wall, and the third motor is hinged with the third hinged arm on the inner side wall, the upper surface of the third hinged arm is in threaded connection with the fourth motor through screws, the output shaft of the fourth motor is welded with the lower surface of the object placing table, the inner side wall of the object placing table is in threaded connection with the servo motor through screws, the output shaft of the servo motor is welded with the inner side wall of the conical worm wheel, the gear teeth of the conical worm wheel are meshed with the gear teeth of the three conical worms, the inner side wall of each conical worm is in threaded connection with the lead screw, the outer surface of the lead screw is in threaded connection with the inner side wall of the sliding block, the upper surface of the sliding block is welded with the asynchronous motor, the output shaft of the asynchronous motor is symmetrically provided with two electric push rods, piston rods of the electric push rods are welded with brackets, and the upper surface of;
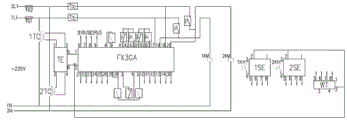
and the electrical output end of the controller is electrically connected with the electrical input ends of the first motor, the second motor, the third motor, the fourth motor, the asynchronous motor and the electric push rod.
As further preferable in the present technical solution: the inner side wall of the object placing table is embedded with an end cover, a rectangular groove is formed in the outer surface of the end cover in an even and annular mode, and the inner side wall of the rectangular groove is matched with the outer surface of the sliding block.
As further preferable in the present technical solution: the outer surface of the end cover is provided with three illuminating lamps, and the electrical output end of the controller is electrically connected with the electrical input ends of the illuminating lamps.
As further preferable in the present technical solution: the even integrated into one piece of inside wall annular of putting the thing platform has the slide rail, the surface of slide rail with the inside wall sliding connection of slider.
As further preferable in the present technical solution: the upper surface of an output shaft of the asynchronous motor is welded with a guide rail, and the outer surface of the guide rail is connected with the inner side wall of the support frame in a sliding mode.
As further preferable in the present technical solution: the carrying mechanism comprises a frame, a hanger, two fifth motors, a gear, a toothed belt and a support frame;
the upper surface of the frame is welded with the lower surface of the hanger, the inner top wall of the hanger is symmetrically installed with the two fifth motors, the output shafts of the fifth motors are welded with the inner side wall of the gear, the gear teeth of the gear are meshed with the tooth surface of the toothed belt, the outer surface of the toothed belt is welded with the upper surface of the supporting frame, and the inner side wall of the supporting frame is welded with the inner side wall of the first supporting plate;
and the electrical output end of the controller is electrically connected with the electrical input end of the fifth motor.
As further preferable in the present technical solution: six wheels are installed to the both sides face symmetry of frame, the last surface mounting of frame has the battery, the electrical property input of controller with the electrical property output electric connection of battery.
As further preferable in the present technical solution: the rear surface mounting of frame has around the roller, around the surface of roller with the surface wraparound of cogged belt connects, the outer skin weld of gallows has the tensioning roller, the surface of tensioning roller with the surface laminating of cogged belt.
Compared with the prior art, the invention has the beneficial effects that:
the clamping mechanism is characterized in that a servo motor, a bevel worm wheel, a bevel worm, a lead screw, a sliding block and calipers in the clamping mechanism are matched, so that the requirements of simultaneously loading multiple groups of welding parts for clamping and displacement splicing are met, the requirement of accurate centering of the distance between the parts can be met by the bevel worm wheel during displacement, and the relative angle between each part can be randomly adjusted by an asynchronous motor, so that a worker is assisted to complete a welding task;
secondly, a plurality of groups of hinged arms of the clamping mechanism are matched with each other, so that the clamping workpiece can be adjusted at any angle compared with the working position of a worker, the requirement that the worker can make any required adjustment according to the actual processing conditions of different parts is met, and the requirement on wide applicability is met;
the conveying mechanism can be used for carrying the clamping mechanism to meet the moving requirement, the horizontal height adjustment of the clamping mechanism is realized by means of the cooperation between the toothed belt, the supporting frame and the like, the horizontal height adjustment of the clamping mechanism is assisted to meet any requirements of working personnel for the actual processing conditions of different parts, compared with the prior art, the conveying mechanism can be used for carrying out any adjustment and clamping according to the welding requirements of workpieces under the actual conditions and the welding posture requirements of the working personnel, the welding work is assisted to be completed, and the working efficiency and the welding precision are greatly improved.
Drawings
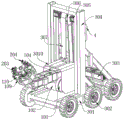
FIG. 1 is a schematic view of a perspective structure according to the present invention;
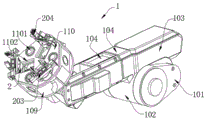
FIG. 2 is a schematic perspective view of another embodiment of the present invention;
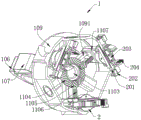
FIG. 3 is a perspective view of the clamping mechanism of the present invention;
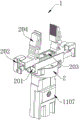
FIG. 4 is a schematic view of another perspective structure of the clamping mechanism of the present invention;
FIG. 5 is a schematic perspective view of the object placing table according to the present invention;
FIG. 6 is a schematic perspective view of an asynchronous motor according to the present invention;
FIG. 7 is a perspective view of the carrying mechanism of the present invention;
FIG. 8 is a schematic perspective view of the enlarged A-zone of FIG. 7 according to the present invention;
FIG. 9 is a circuit diagram of the present invention;
in the figure: 1. a clamping mechanism; 101. a first supporting plate; 102. a first motor; 103. a first hinge arm; 104. a second motor; 105. a second hinge arm; 106. a third motor; 107. a third hinge arm; 108. a fourth motor; 109. a placing table; 1091. a slide rail; 110. an end cap; 1101. an illuminating lamp; 1102. a rectangular groove; 1103. a servo motor; 1104. a bevel worm gear; 1105. a conical worm; 1106. a lead screw; 1107. a slider; 2. an asynchronous motor; 201. an electric push rod; 202. a support frame; 203. a guide rail; 204. a caliper; 3. a carrying mechanism; 301. a frame; 302. a wheel; 303. a storage battery; 304. a hanger; 305. a fifth motor; 306. a gear; 307. a toothed belt; 308. winding the roller; 309. a tension roller; 3010. a support frame; 4. and a controller.
Detailed Description
The technical solutions in the embodiments of the present invention will be clearly and completely described below with reference to the drawings in the embodiments of the present invention, and it is obvious that the described embodiments are only a part of the embodiments of the present invention, and not all of the embodiments. All other embodiments, which can be derived by a person skilled in the art from the embodiments given herein without making any creative effort, shall fall within the protection scope of the present invention.
Examples
Referring to fig. 1-9, the present invention provides a technical solution: a clamping device for fusion welding of automobile parts comprises a clamping mechanism 1, a carrying mechanism 3 and a controller 4, wherein the clamping mechanism 1 comprises a first supporting plate 101, a first motor 102, a first hinge arm 103, a second motor 104, a second hinge arm 105, a third motor 106, a third hinge arm 107, a fourth motor 108, a placing table 109, a servo motor 1103, a bevel worm wheel 1104, three bevel worms 1105, three lead screws 1106, three sliders 1107 and three asynchronous motors 2, the first supporting plate 101 is internally connected with the first motor 102 through screw threads, the upper surface of the first supporting plate 101 is welded with the lower surface of the first hinge arm 103, the front surface of the first hinge arm 103 is connected with the second motor 104 through screw threads, the output shaft of the second motor 104 is welded with the inner side wall of the second hinge arm 105, the inner side wall of the second hinge arm 105 is connected with the third motor 106 through screw threads, and the output shaft of the third motor 106 is hinged with the inner side wall of the third hinge arm 107, the upper surface of the third hinge arm 107 is in threaded connection with a fourth motor 108 through screws, an output shaft of the fourth motor 108 is welded with the lower surface of the object placing table 109, the inner side wall of the object placing table 109 is in threaded connection with a servo motor 1103 through screws, an output shaft of the servo motor 1103 is welded with the inner side wall of a bevel worm wheel 1104, gear teeth of the bevel worm wheel 1104 are meshed with gear teeth of three bevel worms 1105, the inner side wall of the bevel worm 1105 is in threaded connection with a lead screw 1106, the outer surface of the lead screw 1106 is in threaded connection with the inner side wall of a sliding block 1107, an asynchronous motor 2 is welded on the upper surface of the sliding block 1107, two electric push rods 201 are symmetrically installed on the output shaft of the asynchronous motor 2, a piston rod of each electric;
the electrical output end of the controller 4 is electrically connected with the electrical input ends of the first motor 102, the second motor 104, the third motor 106, the fourth motor 108, the asynchronous motor 2 and the electric push rod 201.
In this embodiment, specifically: an end cover 110 is embedded on the inner side wall of the object placing table 109, a rectangular groove 1102 is uniformly and annularly formed in the outer surface of the end cover 110, and the inner side wall of the rectangular groove 1102 is matched with the outer surface of the sliding block 1107; the end cap 110 is responsible for sealing the platform 109 from dust, and when the slide 1107 is in the process of displacement, the platform 109 can use the rectangular slot 1102 mechanism without affecting the normal operation of the slide 1107.
In this embodiment, specifically: three illuminating lamps 1101 are mounted on the outer surface of the end cover 110, and the electrical output end of the controller 4 is electrically connected with the electrical input end of the illuminating lamps 1101; the illumination lamps 1101 may assist the worker in the task lighting requirements of the weldment placed on the stand 109 and end cap 110.
In this embodiment, specifically: a sliding rail 1091 is annularly and uniformly and integrally formed on the inner side wall of the object placing table 109, and the outer surface of the sliding rail 1091 is in sliding connection with the inner side wall of the sliding block 1107; the sliding rail 1091 is responsible for providing a limit for the displacement of the sliding block 1107, so that the sliding block 1107 can be in threaded fit with the lead screw 1106 to meet the requirement of feed motion.
In this embodiment, specifically: the upper surface of the output shaft of the asynchronous motor 2 is welded with a guide rail 203, and the outer surface of the guide rail 203 is connected with the inner side wall of the support frame 202 in a sliding manner; the guide rails 203 can be responsible for providing a limit requirement for the displacement of the supporting frame 202, and can assist in meeting the requirement of the clamping work.
In this embodiment, specifically: the carrying mechanism 3 comprises a frame 301, a hanger 304, two fifth motors 305, a gear 306, a toothed belt 307 and a support frame 3010;
the upper surface of the frame 301 is welded with the lower surface of the hanger 304, the top wall inside the hanger 304 is symmetrically installed with two fifth motors 305, the output shafts of the fifth motors 305 are welded with the inner side walls of the gears 306, the gear teeth of the gears 306 are meshed with the tooth surfaces of the toothed belts 307, the outer surfaces of the toothed belts 307 are welded with the upper surface of the supporting frame 3010, and the inner side walls of the supporting frame 3010 are welded with the inner side walls of the first supporting plate 101;
an electrical output terminal of the controller 4 is electrically connected to an electrical input terminal of the fifth motor 305;
the gear 306 is controlled to rotate by using the output shaft of the fifth motor 305 in the carrying mechanism 3, so that the toothed belt 307 is driven to lift or descend in a meshed manner, the supporting frame 3010 is driven to be matched to adjust the horizontal height of the clamping mechanism 1, and any requirements of working personnel on the actual processing conditions of different parts are met in an auxiliary manner.
In this embodiment, specifically: six wheels 302 are symmetrically arranged on two side surfaces of the frame 301, a storage battery 303 is arranged on the upper surface of the frame 301, and an electrical input end of the controller 4 is electrically connected with an electrical output end of the storage battery 303; the movement requirement is realized for the vehicle frame 301 through the wheels 302.
In this embodiment, specifically: a winding roller 308 is arranged on the rear surface of the frame 301, the outer surface of the winding roller 308 is in winding connection with the outer surface of the toothed belt 307, a tensioning roller 309 is welded on the outer surface of the hanger 304, and the outer surface of the tensioning roller 309 is attached to the outer surface of the toothed belt 307; the toothed belt 307 is stored on the winding roller 308, and the transmission angle coefficient of the toothed belt 307 to the winding roller 308 can be increased by the tension roller 309 cooperating with the toothed belt 307, thereby stabilizing the operation of the belt transmission mechanism.
In this embodiment, specifically: the specific model of the controller 4 is FX3 GA; the specific model of the first electric machine 102 is 1TL 0001; the specific model of the second motor 104 is DS-25RS 370; the specific model of the third motor 106 is ZDF3-25H 20; the specific model of the fourth motor 108 is ACM 2072907; the specific model of the asynchronous motor 2 is YZS-10-4; the specific model of the electric push rod 201 is QDA 60; the fifth motor 305 is specifically of the type HFF80B4B 5.
Working principle or structural principle: a workpiece to be welded is placed between the calipers 204, the controller 4 controls the electric push rod 201 to start, the calipers 204 clamp the workpiece, the preset program recorded by the controller 4 corresponds to the designated welding angle of the workpiece, the asynchronous motor 2 is controlled to adjust the relative angle between the workpiece and the workpiece, the output shaft of the servo motor 1103 controls the bevel worm wheel 1104 to rotate, each bevel worm 1105 and the lead screw 1106 thereof are driven to rotate by meshing, so that each sliding block 1107 and the asynchronous motor 2 are driven to perform feed motion, the synchronous adjustment of the distance between each group of workpieces is realized, meanwhile, the guide rail 203 can be responsible for providing a limit requirement for the displacement of the strut 202, and the requirement for clamping work is met in an auxiliary manner;
after preset welding seams among workpieces are butted, a worker can control the output of the first motor 102, the second motor 104, the third motor 106 and the fourth motor 108 through the controller 4 to adjust the angles among the first hinge arm 103, the second hinge arm 105, the third hinge arm 107 and the object placing table 109 in the clamping mechanism 1, so that the workpiece to be clamped can be adjusted at any angle compared with the working position of the worker, the adjustment of the worker according to any requirement on the actual processing conditions of different parts is met, and the requirement on wide applicability is met;
the gear 306 is controlled to rotate by using the output shaft of the fifth motor 305 in the carrying mechanism 3, so that the toothed belt 307 is driven to lift or descend in a meshed manner, the supporting frame 3010 is driven to be matched to adjust the horizontal height of the clamping mechanism 1, and any requirements of working personnel on the actual processing conditions of different parts are met in an auxiliary manner;
compared with the prior art, the invention can carry out arbitrary adjustment and clamping according to the welding requirements of workpieces and the welding posture requirements of workers under actual conditions, assists in completing welding work, and greatly improves the working efficiency and the welding precision.
Although embodiments of the present invention have been shown and described, it will be appreciated by those skilled in the art that changes, modifications, substitutions and alterations can be made in these embodiments without departing from the principles and spirit of the invention, the scope of which is defined in the appended claims and their equivalents.
Claims (8)
1. The utility model provides an automobile parts clamping device for fusion welding, includes that pincers solid mechanism (1), carrying mechanism (3) and controller (4), its characterized in that: the clamp fixing mechanism (1) comprises a first supporting plate (101), a first motor (102), a first hinged arm (103), a second motor (104), a second hinged arm (105), a third motor (106), a third hinged arm (107), a fourth motor (108), a storage table (109), a servo motor (1103), a bevel worm wheel (1104), three bevel worms (1105), three lead screws (1106), three sliders (1107) and three asynchronous motors (2), wherein the inside of the first supporting plate (101) is in threaded connection with the first motor (102), the upper surface of the first supporting plate (101) is welded with the lower surface of the first hinged arm (103), the front surface of the first hinged arm (103) is in threaded connection with the second motor (104) through screws, the output shaft of the second motor (104) is welded with the inner side wall of the second hinged arm (105), and the inner side wall of the second hinged arm (105) is in threaded connection with the third motor (106), the output shaft of the third motor (106) is hinged to the inner side wall of the third hinged arm (107), the upper surface of the third hinged arm (107) is connected with the fourth motor (108) through screw threads, the output shaft of the fourth motor (108) is welded to the lower surface of the object placing table (109), the inner side wall of the object placing table (109) is connected with the servo motor (1103) through screw threads, the output shaft of the servo motor (1103) is welded to the inner side wall of the cone worm wheel (1104), the gear teeth of the cone worm wheel (1104) are meshed with the gear teeth of the three cone worms (1105), the inner side wall of the cone worm (1105) is connected with the lead screw (1106) through screw threads, the outer surface of the lead screw (1106) is connected with the inner side wall of the slide block (1107), the upper surface of the slide block (1107) is welded with an asynchronous motor (2), and two electric push rods (201) are symmetrically installed on the output shaft of the asynchronous motor (2), a piston rod of the electric push rod (201) is welded with a support frame (202), and the upper surface of the support frame (202) is welded with a caliper (204);
the electric output end of the controller (4) is electrically connected with the electric input ends of the first motor (102), the second motor (104), the third motor (106), the fourth motor (108), the asynchronous motor (2) and the electric push rod (201).
2. The clamping device for fusion welding of automobile parts according to claim 1, characterized in that: the inner side wall of the object placing table (109) is connected with an end cover (110) in an embedded mode, a rectangular groove (1102) is formed in the outer surface of the end cover (110) in an even and annular mode, and the inner side wall of the rectangular groove (1102) is matched with the outer surface of the sliding block (1107).
3. The clamping device for fusion welding of automobile parts as claimed in claim 2, wherein: the outer surface of the end cover (110) is provided with three illuminating lamps (1101), and the electrical output end of the controller (4) is electrically connected with the electrical input end of the illuminating lamps (1101).
4. The clamping device for fusion welding of automobile parts according to claim 1, characterized in that: the inside wall annular of putting thing platform (109) evenly integrated into one piece has slide rail (1091), the surface of slide rail (1091) with the inside wall sliding connection of slider (1107).
5. The clamping device for fusion welding of automobile parts according to claim 1, characterized in that: the upper surface of an output shaft of the asynchronous motor (2) is welded with a guide rail (203), and the outer surface of the guide rail (203) is connected with the inner side wall of the support frame (202) in a sliding mode.
6. The clamping device for fusion welding of automobile parts according to claim 1, characterized in that: the carrying mechanism (3) comprises a frame (301), a hanger (304), two fifth motors (305), a gear (306), a toothed belt (307) and a support frame (3010);
the upper surface of the frame (301) is welded with the lower surface of the hanger (304), the inner top wall of the hanger (304) is symmetrically installed with the two fifth motors (305), the output shafts of the fifth motors (305) are welded with the inner side wall of the gear (306), the teeth of the gear (306) are meshed with the tooth surface of the toothed belt (307), the outer surface of the toothed belt (307) is welded with the upper surface of the supporting frame (3010), and the inner side wall of the supporting frame (3010) is welded with the inner side wall of the first supporting plate (101);
and the electrical output end of the controller (4) is electrically connected with the electrical input end of the fifth motor (305).
7. The clamping device for fusion welding of automobile parts as claimed in claim 6, wherein: six wheels (302) are installed to the both sides face symmetry of frame (301), the last surface mounting of frame (301) has battery (303), the electrical property input of controller (4) with the electrical property output electric connection of battery (303).
8. The clamping device for fusion welding of automobile parts as claimed in claim 6, wherein: the rear surface mounting of frame (301) has around roller (308), around the surface of roller (308) with the surface wraparound of cogged belt (307), the outer skin weld of gallows (304) has tensioning roller (309), the surface of tensioning roller (309) with the surface laminating of cogged belt (307).
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110287885.8A CN112975252A (en) | 2021-03-17 | 2021-03-17 | Clamping device for fusion welding of automobile parts |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110287885.8A CN112975252A (en) | 2021-03-17 | 2021-03-17 | Clamping device for fusion welding of automobile parts |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN112975252A true CN112975252A (en) | 2021-06-18 |
Family
ID=76333449
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202110287885.8A Withdrawn CN112975252A (en) | 2021-03-17 | 2021-03-17 | Clamping device for fusion welding of automobile parts |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN112975252A (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120055706A (en) * | 2025-04-29 | 2025-05-30 | 山东新宇科技发展有限公司 | Pump housing production welding set |
-
2021
- 2021-03-17 CN CN202110287885.8A patent/CN112975252A/en not_active Withdrawn
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120055706A (en) * | 2025-04-29 | 2025-05-30 | 山东新宇科技发展有限公司 | Pump housing production welding set |
| CN120055706B (en) * | 2025-04-29 | 2025-08-08 | 山东新宇科技发展有限公司 | A pump casing production welding device |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN210232292U (en) | Machining clamp for large workpiece | |
| CN118417808B (en) | A high-coordination CNC machining and welding machine tool | |
| CN209125127U (en) | A kind of laser cutting welder | |
| CN115091086A (en) | Welding line for air suspension bracket seat plate | |
| CN116851988A (en) | Automatic surfacing equipment and welding method for sealing surface of valve body | |
| CN107824928B (en) | Four-axis automatic tin welder | |
| CN109909594A (en) | A kind of Full-automatic plasma tunnel bonding machine | |
| CN218016589U (en) | Welding line for seat plate of air suspension bracket | |
| CN209125128U (en) | A kind of laser cutting device | |
| CN106141548A (en) | guardrail automatic welding device | |
| CN211680650U (en) | Welding machine | |
| CN104139149A (en) | Automatic hinge riveting machine | |
| CN217750032U (en) | Automatic welding device of industrial robot | |
| CN216151621U (en) | Movable butt joint device for mechanical welding processing | |
| CN203992229U (en) | Hinge automatic riveting machine | |
| CN214134688U (en) | A intelligent welding set for aluminium alloy processing | |
| CN121104539A (en) | A positioning device and process for producing electrical cabinet frame steel | |
| CN214052672U (en) | A high-speed sorting device based on machine vision | |
| CN212384794U (en) | An automatic argon arc welding device | |
| CN210649241U (en) | Welding tool for machining automobile swing arm | |
| CN217942312U (en) | Six longmen automatic welder | |
| CN207255558U (en) | A kind of rearview mirror welding tooling | |
| CN206605185U (en) | A kind of movement in a curve servo slide table | |
| CN216288486U (en) | Battery string EL repairing machine | |
| CN112139668B (en) | Corrugated welding device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| WW01 | Invention patent application withdrawn after publication |
Application publication date: 20210618 |
|
| WW01 | Invention patent application withdrawn after publication |