CN112757254A - Automatic robot of dismantling of high-voltage line rubber skin - Google Patents
Automatic robot of dismantling of high-voltage line rubber skin Download PDFInfo
- Publication number
- CN112757254A CN112757254A CN202110229571.2A CN202110229571A CN112757254A CN 112757254 A CN112757254 A CN 112757254A CN 202110229571 A CN202110229571 A CN 202110229571A CN 112757254 A CN112757254 A CN 112757254A
- Authority
- CN
- China
- Prior art keywords
- pulley
- support
- skin
- rubber sheet
- wire
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Withdrawn
Links
- 238000009434 installation Methods 0.000 claims description 10
- 238000012937 correction Methods 0.000 claims description 3
- 230000001360 synchronised effect Effects 0.000 claims description 3
- 238000005096 rolling process Methods 0.000 claims description 2
- 230000009286 beneficial effect Effects 0.000 abstract description 3
- 238000003912 environmental pollution Methods 0.000 abstract description 2
- 238000012423 maintenance Methods 0.000 description 4
- 238000013461 design Methods 0.000 description 2
- 238000009413 insulation Methods 0.000 description 2
- 230000005540 biological transmission Effects 0.000 description 1
- 230000006835 compression Effects 0.000 description 1
- 238000007906 compression Methods 0.000 description 1
- 239000004020 conductor Substances 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 239000000945 filler Substances 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 238000012545 processing Methods 0.000 description 1
- 230000001681 protective effect Effects 0.000 description 1
Images





Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J5/00—Manipulators mounted on wheels or on carriages
- B25J5/007—Manipulators mounted on wheels or on carriages mounted on wheels
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J11/00—Manipulators not otherwise provided for
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02G—INSTALLATION OF ELECTRIC CABLES OR LINES, OR OF COMBINED OPTICAL AND ELECTRIC CABLES OR LINES
- H02G1/00—Methods or apparatus specially adapted for installing, maintaining, repairing or dismantling electric cables or lines
- H02G1/12—Methods or apparatus specially adapted for installing, maintaining, repairing or dismantling electric cables or lines for removing insulation or armouring from cables, e.g. from the end thereof
- H02G1/1202—Methods or apparatus specially adapted for installing, maintaining, repairing or dismantling electric cables or lines for removing insulation or armouring from cables, e.g. from the end thereof by cutting and withdrawing insulation
- H02G1/1248—Machines
- H02G1/1251—Machines the cutting element not rotating about the wire or cable
Landscapes
- Engineering & Computer Science (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Manipulator (AREA)
Abstract
A high-voltage line rubber skin automatic disassembling robot comprises: the intelligent walking platform, the wire peeling mechanism and the wire skin collecting mechanism; the intelligent walking platform is used as a frame, the intelligent walking platform can automatically walk on a high-voltage wire and carry a plurality of devices, the carried devices can be intelligently controlled, the wire peeling mechanism is fixedly arranged at the front part of the intelligent walking platform, a plurality of parts in the wire peeling mechanism are matched with each other to realize automatic peeling of the sheath of the high-voltage wire, and the sheath collecting mechanism is fixedly arranged at the tail end of the bottom of the intelligent walking platform to realize the aim of collecting the peeled rubber sheath of the high-voltage wire; the high-voltage wire rubber sheet disassembling device can adapt to various severe working environments, achieves the beneficial effect of automatically disassembling the high-voltage wire rubber sheet, collects the disassembled high-voltage wire rubber sheet, and avoids environmental pollution.
Description
Technical Field
The invention relates to the technical field of electrical mechanical equipment, in particular to a robot for automatically disassembling rubber sheets of high-voltage wires.
Background
The high-voltage cable is one of power cables, is a power cable used for transmitting power between 1kv and 1000kv, is mainly applied to power transmission and distribution, and comprises the following components from inside to outside: conductor, insulation, inner sheath, filler (armor), outer insulation. Certainly, the armored high-voltage cable is mainly used for being buried, can resist the compression of high strength on the ground, can prevent other external force from damaging, needs to cut the protective skin on the outer side at the connecting point of the high-voltage cable, is cut by corresponding tools manually at present, and is low in efficiency and easy to damage the cable.
For example, patent nos.: 201922402165.2 discloses an automatic peeling device for high-voltage cables, which comprises an installation seat and a peeling mechanism, wherein supporting blocks are arranged on two sides of the lower end surface of the installation seat, the peeling mechanism is arranged on the upper end surface of the installation seat, the peeling mechanism is composed of a fixing plate, a fixing rod, an adjusting threaded rod, an installation plate, a plurality of semicircular holes, a blade, a supporting rod and a plurality of peeling sheets, the fixing plate is arranged on one side of the upper end surface of the installation seat, the fixing rod is arranged on two sides of the upper end surface of the fixing plate, the adjusting threaded rod is connected to the fixing rod through a through hole and a thread, and the installation plate is movably arranged at the lower end of the adjusting threaded. The utility model discloses simple structure, reasonable in design can be fast effectual skins the processing to many high-voltage cables, can adjust the depth of cut simultaneously according to the thickness of high-voltage cable protection skin, does not need the manual work to skin simultaneously, improves the efficiency of skinning, alleviates staff's work burden.
However, the automatic peeling device for the high-voltage cable has limited functions, is complicated in structure, causes certain inconvenience in operation, is expensive in maintenance cost and inconvenient in maintenance when a fault occurs, and cannot improve the working efficiency to a large extent, and provides less help for workers.
Therefore, it is urgently needed to design an automatic disassembling robot for rubber sheets of high-voltage wires to solve the problems faced currently.
Disclosure of Invention
In order to solve the above problems, the present invention provides an automatic high voltage line rubber skin detaching robot, including: the intelligent walking platform, the wire peeling mechanism and the wire skin collecting mechanism; the intelligent walking platform is used as a frame, the intelligent walking platform can automatically walk on a high-voltage wire and carry a plurality of devices, the carried devices can be intelligently controlled, the wire peeling mechanism is fixedly arranged at the front part of the intelligent walking platform, a plurality of parts in the wire peeling mechanism are matched with each other to realize automatic peeling of the sheath of the high-voltage wire, and the sheath collecting mechanism is fixedly arranged at the tail end of the bottom of the intelligent walking platform to realize the aim of collecting the peeled rubber sheath of the high-voltage wire; the high-voltage wire rubber sheet disassembling device can adapt to various severe working environments, achieves the beneficial effect of automatically disassembling the high-voltage wire rubber sheet, collects the disassembled high-voltage wire rubber sheet, and avoids environmental pollution.
In order to achieve the purpose, the invention adopts the following technical scheme: a high-voltage line rubber skin automatic disassembling robot comprises: the intelligent walking platform and the wire stripping mechanism; the intelligent walking platform is taken as a frame, the intelligent walking platform is provided with at least two rollers and rides on a high-voltage line, the wire peeling mechanism is provided with a cutting knife rest and an air pump support, the cutting knife rest is fixedly arranged at the front end of the top of the intelligent walking platform, and the air pump support is fixedly arranged in the middle of the intelligent walking platform; the wire peeling mechanism can automatically peel off the outer skin of the high-voltage wire.
Preferably, the frame among the intelligence walking platform sets up two at least assembly pulley mounting brackets, fixed mounting has the pulley support in the assembly pulley mounting bracket in the frame, the inside pulley installation position that is provided with of pulley support, the last roll of pulley installation position is installed the pulley, fixed mounting has the pulley motor to be used for driving the pulley rotation on the pulley installation position of the inside setting of pulley support.
Preferably, the left side and the right side of the bottom of the pulley support are fixedly provided with a limiting wheel support in a lining mode, a limiting wheel is rotatably arranged inside the limiting wheel support, the front end of the top of the rack is fixedly provided with a PLC, and the front surface of the PLC is provided with a radar correction instrument.
Preferably, cutting knife rest fixed mounting in the wire peeling mechanism is in PLC programming controller bottom, fixed mounting has the cutting knife in the middle of the cutting knife rest bottom, fixed surface installs the air pump support on the bottom of frame middle part, the pneumatic cylinder is installed in the rotation of air pump support top, air pump support top front end fixed mounting has the pivot support, rotate on the pivot support and install the pivot, the pneumatic cylinder output rotates with the pivot top and is connected.
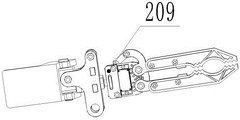
Preferably, the front end of the rotating shaft is fixedly provided with calipers, and the calipers are provided with a caliper tightness motor and a caliper rotating motor.
Preferably, a baffle slide rail is fixedly mounted at the bottom of the front end of the rack, a pair of baffles is slidably mounted inside the baffle slide rail, a telescopic rod motor support is fixedly mounted at the bottom of the rack, two telescopic rod motors are fixedly mounted on the left side and the right side of the telescopic rod motor support respectively, and a telescopic rod is mounted between the lower end of each baffle and the corresponding telescopic rod motor.
Preferably, a high-voltage line rubber skin automatic disassembly robot still includes: a bobbin thread collecting mechanism; mechanism support fixed mounting is collected to line skin in the mechanism in the frame bottom, both ends are rotated around the line skin is collected mechanism support is inside and are installed and collect wheel support and guide pulley support to connect through the linking arm and realize synchronous motion, the line skin is collected mechanism support one side fixed mounting motor A, motor A output runs through the line skin and is collected mechanism support and drive and collect the wheel rotation, the line skin is collected mechanism support bottom and is rotated and install and collect the wheel, it passes through the motor B drive to collect the wheel, guide pulley support bottom is rotated and is installed the guide pulley.
Preferably, the front end of the wire skin collecting mechanism support is rotatably provided with a skin cutting knife rest, one side of the wire skin collecting mechanism support is fixedly provided with a cutter motor, the output end of the cutter motor penetrates through the wire skin collecting mechanism support to drive the skin cutting knife rest to rotate, and the rear end of the skin cutting knife rest is fixedly provided with a skin cutting knife.
Due to the adoption of the technical scheme, the invention has the following advantages:
(1) the automatic walking platform can automatically walk on a high-voltage wire, can carry out all-dimensional scanning on working conditions, prevents the high-voltage wire from being separated from the pulley by designing the matching of the pulley and the limiting wheel, realizes the beneficial effect of automatically disassembling the rubber skin of the high-voltage wire by matching the cutting knife and the calipers, and can adapt to various severe working environments.
(2) According to the invention, by designing the baffle plate structure, the swinging range of the rubber sheet of the high-voltage wire is controllable after the rubber sheet is detached, and the rubber sheet is easy to collect.
(3) According to the invention, the collection of the rubber skin of the high-voltage wire is realized through the matching of the collection wheel, the skin cutter and the guide wheel in the skin collection mechanism, and the pollution is avoided.
Drawings
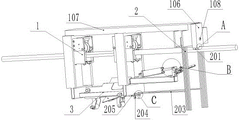
Fig. 1 is a schematic view of the overall structure of the present invention.
FIG. 2 is a schematic view of another angle structure of the present invention.
Fig. 3 is a schematic structural diagram of the pulley block.
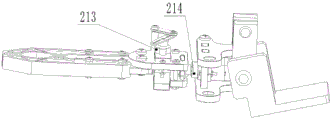
FIG. 4 is a schematic view of a caliper according to the present invention.
Fig. 5 is a schematic view of the rack structure of the present invention.
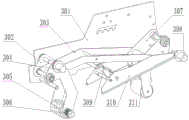
FIG. 6 is a schematic view of the collecting mechanism of the invention.
FIG. 7 is a schematic view of a structure shown in FIG. A.
FIG. 8 is an enlarged view of the structure at B in the first embodiment of the present invention.
FIG. 9 is an enlarged view of a structure at a point C in the drawing.
Fig. 10 is a schematic view of the position of the cutting tool body of the present invention.
FIG. 11 is a bottom view of the caliper of the present invention.
Reference numerals: 1-an intelligent walking platform; 101-a pulley carriage; 102-a pulley; 103-a pulley motor; 104-a spacing wheel bracket; 105-a spacing wheel; 106-PLC programming controller; 107-a frame; 108-radar rectification equipment; 109-a pulley block mounting rack; 2-a wire stripping mechanism; 201-a cutting blade holder; 202-a cutting knife; 203-a telescopic rod; 204-a telescopic rod motor; 205-telescopic rod motor support; 206-hydraulic cylinder; 207-baffle slide rail; 208-a baffle; 209-calipers; 210-a rotating shaft; 211-a spindle support; 212-air pump support; 213-caliper take-up motor; 214-caliper rotating electrical machine; 3-a thread skin collecting mechanism; 301-a wire skin collection mechanism support; 302-collection wheel holder; 303-a linker arm; 304-Motor A; 305-a collection wheel; 306-motor B; 307-an idler yoke; 308-a cutter motor; 309-dermatotome; 310-a dermatome cutter frame; 311-guide wheels.
Detailed Description
The technical scheme of the invention is further specifically described by the following embodiments and the accompanying drawings. In the following description, numerous specific details are set forth in order to provide a thorough understanding of the present invention, but the present invention may be practiced in many ways other than those described herein, and it will be apparent to those skilled in the art that similar modifications can be made without departing from the spirit of the invention, and therefore the invention is not limited to the specific embodiments disclosed below.
In the description of the present invention, it should be noted that the terms "upper", "lower", "front", "back", "left", "right", and the like indicate orientations or positional relationships based on orientations or positional relationships shown in the drawings or orientations or positional relationships that the products of the present invention are conventionally placed in use, and are only used for convenience in describing the present invention and simplifying the description, but do not indicate or imply that the devices or elements referred to must have a specific orientation, be constructed in a specific orientation, and be operated, and thus, should not be construed as limiting the present invention.
Embodiment, as shown in fig. 1 to 11, an automatic rubber sheet removing robot for high voltage line includes: the intelligent walking platform 1, the wire peeling mechanism 2 and the wire skin collecting mechanism 3; the automatic high-voltage wire rubber skin detaching robot is different from the existing high-voltage wire rubber skin detaching robot, so that a user needs to be clearly informed of the working principle of the robot in advance during use and maintenance, namely: the intelligent walking platform 1 controls the wire peeling mechanism 2 and the wire skin collecting mechanism 3 to automatically disassemble and collect the rubber skin of the high-voltage wire; thereby avoiding improper use or improper maintenance;
the intelligent walking platform 1 is taken as a frame, the intelligent walking platform 1 is provided with at least two rollers 102 and rides on a high-voltage line, the wire peeling mechanism 2 is provided with a cutting knife rest 201 and an air pump support 212, the cutting knife rest 201 is fixedly arranged at the front end of the top of the intelligent walking platform 1, and the air pump support 212 is fixedly arranged in the middle of the intelligent walking platform 1; the wire stripping mechanism 2 can automatically strip the outer skin of the high-voltage wire.
In another embodiment of this embodiment, the frame 107 in the intelligent walking platform 1 is provided with at least two pulley block mounting frames 109, a pulley support 101 is fixedly mounted in the pulley block mounting frame 109 in the frame 107, a pulley mounting position is arranged inside the pulley support 101, a pulley 102 is installed on the pulley mounting position in a rolling manner, and a pulley motor 103 is fixedly mounted on the pulley mounting position arranged inside the pulley support 101 and used for driving the pulley 102 to rotate.
In another embodiment of this embodiment, a limiting wheel support 104 is symmetrically and fixedly mounted on the left and right of the bottom of the pulley support 101, a limiting wheel 105 is rotatably mounted inside the limiting wheel support 104, the limiting wheel 105 can prevent the pulley 102 from breaking away from a high-voltage line when moving forward, a PLC programming controller 106 is fixedly mounted at the front end of the top of the frame 107 and controls the whole mechanism, a radar corrector 108 is arranged on the front surface of the PLC programming controller 106, and the PLC programming controller 106 is provided with the radar corrector 108 through the front surface and can scan and image the working environment.
In another embodiment of this embodiment, the cutting blade holder 201 of the wire peeling mechanism 2 is fixedly mounted at the bottom of the PLC programming controller 106, the cutting blade 202 is fixedly mounted in the middle of the bottom of the cutting blade holder 201, the air pump bracket 212 is fixedly mounted on the upper surface of the middle bottom of the rack 107, the hydraulic cylinder 206 is rotatably mounted at the top of the air pump bracket 212, the rotating shaft bracket 211 is fixedly mounted at the front end of the top of the air pump bracket 212, the rotating shaft 210 is rotatably mounted on the rotating shaft bracket 211, and the output end of the hydraulic cylinder 206 is rotatably connected with.
In another embodiment of this embodiment, a caliper 209 is fixedly mounted at the front end of the rotating shaft 210, a caliper tightening motor 213 and a caliper rotating motor 214 are arranged on the caliper 209, when the cutting knife 202 in the wire peeling mechanism 2 cuts the rubber sheet of the high-voltage wire into a cut, the hydraulic cylinder 206 is started at this time to drive the caliper 209 to lift up, when the caliper 209 contacts the rubber sheet of the high-voltage wire, the caliper tightening motor 213 is started to control the caliper to clamp the rubber sheet of the high-voltage wire, then the caliper rotating motor drives the caliper 209 to rotate left and right to peel off the outer skin, and the hydraulic cylinder 206 is started to drive the caliper 209 to descend;
in another embodiment of this embodiment, a baffle slide rail 207 is fixedly installed at the bottom of the front end of the rack 107, a pair of baffles 208 is slidably installed inside the baffle slide rail 207, an expansion link motor bracket 205 is fixedly installed at the bottom of the rack 107, two expansion link motors 204 are symmetrically and fixedly installed on the left and right sides of the expansion link motor bracket 205, and an expansion link 203 is installed between the lower end of the baffle 208 and the expansion link motor 204; the telescopic rod motor 204 can control the telescopic rod 203 to stretch and retract, and further control the baffle 208 to slide in the baffle slide rail 207, so that the swing range of the stripped high-voltage wire rubber is controlled.
In another embodiment of this embodiment, the hide collecting mechanism 3; mechanism's support 301 fixed mounting is collected to line skin in mechanism 3 in frame 107 bottom, both ends are rotated around the line skin is collected mechanism's support 301 is inside and are installed collection wheel support 302 and guide pulley support 307, and connect through linking arm 303 and realize synchronous motion, mechanism's support 301 one side fixed mounting motor A304 is collected to line skin, motor A304 output runs through line skin and collects mechanism's support 301 and drive collection wheel support 302 and rotate, line skin is collected mechanism's support 301 bottom and is rotated and install collection wheel 305, collection wheel 305 passes through motor B306 drive, guide pulley 311 is installed in guide pulley support 307 bottom rotation.
In another embodiment of this embodiment, the front end of the sheath collecting mechanism bracket 301 is rotatably installed with the sheath cutting knife rest 310, one side of the sheath collecting mechanism bracket 301 is fixedly installed with the cutter motor 308, the output end of the cutter motor 308 penetrates through the sheath collecting mechanism bracket 301 to drive the sheath cutting knife rest 310 to rotate, the rear end of the sheath cutting knife rest 310 is fixedly installed with the sheath cutting knife 309, and the cutter motor 308 drives the sheath cutting knife rest 310 to rotate to cut off the stripped high-voltage wire rubber sheath.
The invention also comprises at least the following advantages:
the starting device, the PLC 106 in the intelligent walking platform 1 scans the working environment through the radar correction instrument 108, then the pulley motor 103 is controlled to start the driving mechanism to advance, the cutting knife 202 in the wire peeling mechanism 2 cuts the rubber skin of the high-voltage wire into a notch, at the moment, the hydraulic cylinder 206 is started to drive the caliper 209 to lift up, when the caliper 209 contacts the rubber skin of the high-voltage wire, the caliper elastic motor 213 is started to control the caliper to clamp the rubber skin of the high-voltage wire, then the caliper rotating motor drives the caliper 209 to rotate left and right to peel off the rubber skin, the hydraulic cylinder 206 is started to drive the caliper 209 to descend to peel off the rubber skin of the high-voltage wire, at the moment, the rubber skin of the high-voltage wire which is successfully peeled off is manually wound on the collecting wheel 305 through the guide wheel 311, the motor B is started to drive the collecting wheel 305 to collect the rubber, the rubber sheets of the high-voltage wire rubber sheets are collected at the collecting wheel 305 through the caliper 209 and the guide wheel 311, when the rubber sheets of the high-voltage wire on the collecting wheel 305 are fully wound, the rubber sheets of the high-voltage wire rubber sheets can be cut off by the skin cutting knife 309, the collecting wheel 305 is inverted, the rubber sheets of the high-voltage wire can be detached, and the purpose of automatically detaching the rubber sheets of the high-voltage wire is achieved.
The above description is only for the preferred embodiment of the present invention, but the scope of the present invention is not limited thereto, and any person skilled in the art should be considered to be within the technical scope of the present invention, and the technical solutions and the inventive concepts thereof according to the present invention should be equivalent or changed within the scope of the present invention.
Claims (8)
1. The utility model provides an automatic dismantlement robot of high-voltage line rubber skin which characterized in that includes: the intelligent walking platform (1) and the wire peeling mechanism (2); the intelligent walking platform (1) is used as a frame, the intelligent walking platform (1) is provided with at least two idler wheels (102) which are arranged on high-voltage lines, the wire peeling mechanism (2) is provided with a cutting knife rest (201) and an air pump support (212), the cutting knife rest (201) is fixedly arranged at the front end of the top of the intelligent walking platform (1), and the air pump support (212) is fixedly arranged in the middle of the intelligent walking platform (1); the wire peeling mechanism (2) can automatically peel the outer skin of the high-voltage wire.
2. The automatic rubber sheet disassembling robot for the high-voltage line according to claim 1, characterized in that at least two pulley block mounting frames (109) are arranged on a rack (107) in the intelligent walking platform (1), a pulley bracket (101) is fixedly mounted in the pulley block mounting frames (109) in the rack (107), a pulley mounting position is arranged inside the pulley bracket (101), a pulley (102) is mounted on the pulley mounting position in a rolling manner, and a pulley motor (103) is fixedly mounted on the pulley mounting position arranged inside the pulley bracket (101) and used for driving the pulley (102) to rotate.
3. The automatic rubber skin dismounting robot for the high-voltage wire according to claim 2, wherein a limiting wheel bracket (104) is fixedly mounted on the bottom of the pulley bracket (101) in a left-right lining mode, a limiting wheel (105) is rotatably mounted inside the limiting wheel bracket (104), a PLC (programmable logic controller) (106) is fixedly mounted at the front end of the top of the machine frame (107), and a radar correction instrument (108) is arranged on the front surface of the PLC (106).
4. The automatic robot of dismantling rubber skin of high-tension line of claim 1, characterized in that, cutting knife rest (201) fixed mounting in PLC programming controller (106) bottom among the wire peeling mechanism (2), fixed mounting has cutting knife (202) in the middle of cutting knife rest (201) bottom, fixed surface mounting has air pump support (212) on the bottom of frame (107) middle part, pneumatic cylinder (206) are installed in the rotation of air pump support (212) top, air pump support (212) top front end fixed mounting has pivot support (211), pivot support (211) are gone up to rotate and are installed pivot (210), pneumatic cylinder (206) output is connected with pivot (210) top rotation.
5. The automatic rubber sheet dismounting robot for the high-voltage wire according to claim 4, wherein a caliper (209) is fixedly mounted at the front end of the rotating shaft (210), and a caliper tightening motor (213) and a caliper rotating motor (214) are arranged on the caliper (209).
6. The automatic rubber sheet dismounting robot for the high-voltage wire according to claim 4, wherein a baffle sliding rail (207) is fixedly mounted at the bottom of the front end of the frame (107), a pair of baffles (208) is slidably mounted inside the baffle sliding rail (207), an expansion link motor bracket (205) is fixedly mounted at the bottom of the frame (107), two expansion link motors (204) are fixedly mounted on the left and right sides of the expansion link motor bracket (205) in a left-right lining manner, and an expansion link (203) is mounted between the lower end of the baffle (208) and the expansion link motor (204).
7. The automatic rubber sheet dismounting robot for high voltage wire as claimed in claim 1, wherein the automatic rubber sheet dismounting robot for high voltage wire further comprises: a wire skin collecting mechanism (3); mechanism support (301) fixed mounting is collected in frame (107) bottom to the line skin in mechanism (3) is collected to the line skin, the line skin is collected mechanism support (301) inside front and back both ends and is rotated installation and collect wheel support (302) and guide pulley bracket (307) to connect through linking arm (303) and realize synchronous motion, the line skin is collected mechanism support (301) one side fixed mounting motor A (304), motor A (304) output runs through line skin and collects mechanism support (301) and drive and collect wheel support (302) and rotate, line skin is collected mechanism support (301) bottom and is rotated and install and collect wheel (305), it drives through motor B (306) to collect wheel (305), guide pulley bracket (307) bottom is rotated and is installed guide pulley (311).
8. The automatic rubber sheet dismounting robot for the high-voltage wire according to claim 6, wherein a rubber sheet cutting knife rest (310) is rotatably mounted at the front end of the rubber sheet collecting mechanism support (301), a cutter motor (308) is fixedly mounted at one side of the rubber sheet collecting mechanism support (301), the output end of the cutter motor (308) penetrates through the rubber sheet collecting mechanism support (301) to drive the rubber sheet cutting knife rest (310) to rotate, and a rubber sheet cutting knife (309) is fixedly mounted at the rear end of the rubber sheet cutting knife rest (310).
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110229571.2A CN112757254A (en) | 2021-03-02 | 2021-03-02 | Automatic robot of dismantling of high-voltage line rubber skin |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202110229571.2A CN112757254A (en) | 2021-03-02 | 2021-03-02 | Automatic robot of dismantling of high-voltage line rubber skin |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN112757254A true CN112757254A (en) | 2021-05-07 |
Family
ID=75690779
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202110229571.2A Withdrawn CN112757254A (en) | 2021-03-02 | 2021-03-02 | Automatic robot of dismantling of high-voltage line rubber skin |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN112757254A (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN118809555A (en) * | 2024-07-16 | 2024-10-22 | 国网江苏省电力有限公司淮安供电分公司 | A kind of live working auxiliary mechanical arm |
-
2021
- 2021-03-02 CN CN202110229571.2A patent/CN112757254A/en not_active Withdrawn
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN118809555A (en) * | 2024-07-16 | 2024-10-22 | 国网江苏省电力有限公司淮安供电分公司 | A kind of live working auxiliary mechanical arm |
| CN118809555B (en) * | 2024-07-16 | 2024-12-17 | 国网江苏省电力有限公司淮安供电分公司 | Hot-line work auxiliary mechanical arm |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN211480769U (en) | Cable stripping machine | |
| CN216874036U (en) | A scalable trimming means for forest is pruned | |
| CN114825159B (en) | Highway tunnel cable maintenance equipment | |
| CN111872036A (en) | Electronic communication waste optical cable inner core recovery device | |
| CN109616957A (en) | A kind of automatic peeling tool and method for peeling insulated wire | |
| CN216883947U (en) | Single-arm man-machine cooperation distribution network live working equipment | |
| CN114024260A (en) | Intelligent cable device of skinning that can independently advance | |
| CN210605111U (en) | Automatic peeling device for optical cable | |
| CN210500437U (en) | Glue peeling machine with waste material separation function | |
| CN221080809U (en) | Power cable stripping device for power engineering | |
| CN221574720U (en) | Peeling device for cable recovery | |
| CN219677971U (en) | Building electrical cable peeling device | |
| CN212392597U (en) | A cable stripping machine with easy diameter adjustment | |
| CN219123828U (en) | Peeling machine | |
| CN113711794B (en) | Telescopic splicing insulation high-branch reciprocating saw | |
| CN116454796A (en) | Special cable stripping device for new energy power generation | |
| CN216929442U (en) | Car wiring harness device of skinning | |
| CN112053811B (en) | Cable core recovery plant | |
| CN217522490U (en) | Stripping device for outer protective layer of insulated cable | |
| CN215267422U (en) | Photovoltaic cable treatment facility | |
| CN210838717U (en) | Wire stripping device for rubber sheath cable | |
| CN218850269U (en) | Power cable wire stripping device for electric power engineering | |
| CN219436530U (en) | Peeling device convenient for wire harness machining | |
| CN221727823U (en) | A cable installation auxiliary device | |
| CN214479148U (en) | Convenient cable rotary-cut device of skinning |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| WW01 | Invention patent application withdrawn after publication | ||
| WW01 | Invention patent application withdrawn after publication |
Application publication date: 20210507 |