CN112590026A - Automatic-guiding stone gap correction cutting method and device thereof - Google Patents
Automatic-guiding stone gap correction cutting method and device thereof Download PDFInfo
- Publication number
- CN112590026A CN112590026A CN202011436808.6A CN202011436808A CN112590026A CN 112590026 A CN112590026 A CN 112590026A CN 202011436808 A CN202011436808 A CN 202011436808A CN 112590026 A CN112590026 A CN 112590026A
- Authority
- CN
- China
- Prior art keywords
- fixedly connected
- starting point
- cutting
- motor
- frame
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
- 238000005520 cutting process Methods 0.000 title claims abstract description 66
- 238000000034 method Methods 0.000 title claims abstract description 27
- 239000004575 stone Substances 0.000 title claims abstract description 22
- 238000012937 correction Methods 0.000 title claims abstract description 13
- 230000007246 mechanism Effects 0.000 claims description 12
- 230000008569 process Effects 0.000 claims description 10
- 238000004140 cleaning Methods 0.000 claims description 9
- 230000001681 protective effect Effects 0.000 claims description 8
- 239000003795 chemical substances by application Substances 0.000 claims description 7
- CSCPPACGZOOCGX-UHFFFAOYSA-N Acetone Chemical compound CC(C)=O CSCPPACGZOOCGX-UHFFFAOYSA-N 0.000 claims description 6
- 239000003638 chemical reducing agent Substances 0.000 claims description 4
- LFQSCWFLJHTTHZ-UHFFFAOYSA-N Ethanol Chemical compound CCO LFQSCWFLJHTTHZ-UHFFFAOYSA-N 0.000 claims description 3
- 239000011248 coating agent Substances 0.000 claims description 3
- 238000000576 coating method Methods 0.000 claims description 3
- 238000012544 monitoring process Methods 0.000 claims description 3
- 239000003973 paint Substances 0.000 claims description 3
- 230000002093 peripheral effect Effects 0.000 claims description 3
- 238000012545 processing Methods 0.000 claims description 3
- 230000035807 sensation Effects 0.000 claims description 3
- 238000009966 trimming Methods 0.000 claims description 3
- 230000008439 repair process Effects 0.000 abstract description 8
- 238000005516 engineering process Methods 0.000 abstract description 3
- 239000002699 waste material Substances 0.000 abstract description 2
- 238000013461 design Methods 0.000 description 8
- 239000000463 material Substances 0.000 description 7
- 239000002969 artificial stone Substances 0.000 description 6
- 238000005034 decoration Methods 0.000 description 5
- 229910000831 Steel Inorganic materials 0.000 description 3
- 238000010276 construction Methods 0.000 description 3
- 239000010438 granite Substances 0.000 description 3
- 239000002994 raw material Substances 0.000 description 3
- 239000010959 steel Substances 0.000 description 3
- 230000008901 benefit Effects 0.000 description 2
- 239000011449 brick Substances 0.000 description 2
- 238000011161 development Methods 0.000 description 2
- 238000010586 diagram Methods 0.000 description 2
- 230000006870 function Effects 0.000 description 2
- 239000010454 slate Substances 0.000 description 2
- 235000019738 Limestone Nutrition 0.000 description 1
- 230000009471 action Effects 0.000 description 1
- 239000007767 bonding agent Substances 0.000 description 1
- 239000004568 cement Substances 0.000 description 1
- 230000008859 change Effects 0.000 description 1
- 230000008878 coupling Effects 0.000 description 1
- 238000010168 coupling process Methods 0.000 description 1
- 238000005859 coupling reaction Methods 0.000 description 1
- 230000007547 defect Effects 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 238000005242 forging Methods 0.000 description 1
- 230000003993 interaction Effects 0.000 description 1
- 230000001678 irradiating effect Effects 0.000 description 1
- 239000006028 limestone Substances 0.000 description 1
- 230000000670 limiting effect Effects 0.000 description 1
- 239000004579 marble Substances 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 230000003287 optical effect Effects 0.000 description 1
- 238000005498 polishing Methods 0.000 description 1
- 238000003825 pressing Methods 0.000 description 1
- 239000011435 rock Substances 0.000 description 1
- -1 sandstone Substances 0.000 description 1
- 230000008054 signal transmission Effects 0.000 description 1
- 239000000126 substance Substances 0.000 description 1
Images


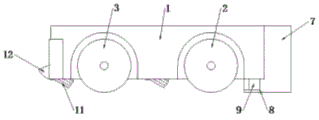

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B28—WORKING CEMENT, CLAY, OR STONE
- B28D—WORKING STONE OR STONE-LIKE MATERIALS
- B28D1/00—Working stone or stone-like materials, e.g. brick, concrete or glass, not provided for elsewhere; Machines, devices, tools therefor
- B28D1/22—Working stone or stone-like materials, e.g. brick, concrete or glass, not provided for elsewhere; Machines, devices, tools therefor by cutting, e.g. incising
- B28D1/24—Working stone or stone-like materials, e.g. brick, concrete or glass, not provided for elsewhere; Machines, devices, tools therefor by cutting, e.g. incising with cutting discs
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B28—WORKING CEMENT, CLAY, OR STONE
- B28D—WORKING STONE OR STONE-LIKE MATERIALS
- B28D7/00—Accessories specially adapted for use with machines or devices of the preceding groups
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B28—WORKING CEMENT, CLAY, OR STONE
- B28D—WORKING STONE OR STONE-LIKE MATERIALS
- B28D7/00—Accessories specially adapted for use with machines or devices of the preceding groups
- B28D7/005—Devices for the automatic drive or the program control of the machines
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0231—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means
- G05D1/0234—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means using optical markers or beacons
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0231—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means
- G05D1/0242—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means using non-visible light signals, e.g. IR or UV signals
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0257—Control of position or course in two dimensions specially adapted to land vehicles using a radar
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Aviation & Aerospace Engineering (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Mechanical Engineering (AREA)
- Electromagnetism (AREA)
- Mining & Mineral Resources (AREA)
- Road Repair (AREA)
Abstract
The invention discloses an automatic guiding stone gap correction cutting method and a device thereof, comprising a moving frame, a power assembly, a steering assembly, a fixed frame, a first radar wave transceiver, a second radar wave transceiver, a starting point base, a starting point control groove, a starting point pile and a cutting assembly; a power assembly and a steering assembly are arranged in the moving frame; a fixed frame is fixedly connected in the movable frame; a plurality of first radar wave transceivers are fixedly connected in the fixed frame; a plurality of starting point piles are fixedly connected to the lower surface of the moving frame; the starting pile is buckled and connected in the starting control groove; the starting point control groove is formed in the starting point base; a cutting assembly is arranged in the movable frame; the function of quick, efficient and accurate gap correction is realized, the problem of low efficiency of traditional manual gap repair is solved, and the gap repair efficiency is improved; the problems that a traditional manual seam repairing device wastes time and labor, is high in cost and is uneven in technology are solved, the compatibility of the seam repairing device is improved, and the seam repairing cost is reduced.
Description
Technical Field
The application relates to a cutting device, in particular to an automatic guiding stone gap correction cutting method and device.
Background
Stone (Stone) is widely applied to indoor and outdoor decoration design, curtain wall decoration and public facility construction as a high-grade building decoration material; common stones in the market at present are mainly divided into natural stones and artificial stones; the natural stone is divided into slate and granite according to the quality of physical and chemical characteristics; the artificial stone is divided into terrazzo and synthetic stone according to the working procedures; the terrazzo is formed by forging and pressing raw materials such as cement, concrete and the like; the synthetic stone is prepared by taking crushed stone of natural stone as a raw material, adding a bonding agent and the like, and pressurizing and polishing; the latter two are made by hand, so the strength is not as high as that of natural stone; the stone is a high-grade product of building decoration materials, natural stones are mainly divided into granite, slate, sandstone, limestone, volcanic rock and the like, along with the continuous development and progress of science and technology, the artificial stone products are also changed day by day, and the quality and the attractiveness of the artificial stone are not changed; with the development of building design, stone has become one of the important raw materials for building, decoration, road and bridge construction.
In the garden engineering, a large amount of garden path paving work needs to be carried out, and the main materials commonly used at present are PC bricks (concrete stone-like bricks), granite, marble and other materials; in the paving process, due to improper operation of workers or the shape problem of the stone, the condition of uneven gaps among the stones often occurs, and the impression effect is influenced; therefore, after the paving and the pasting are finished, a seam repairing and cutting machine is needed to be used for correcting the seam; in the straight plate gap correction operation of the straight line segment, angle steel can be used as a guide material, a guide wheel is installed on the cutting machine, and the angle steel has a limiting effect on the guide wheel, so that the rapid straight line cutting can be realized; however, in the arc-shaped section, because the arc-shaped plates are different in size and radian, the construction cannot be assisted by using guiding tools such as angle steel, the manual joint cutting is long in time consumption and poor in quality, and the rapid and accurate gap correction operation cannot be performed; therefore, an automatic guiding stone gap correction cutting method and device thereof are provided to solve the above problems.
Disclosure of Invention
In order to overcome the defects of the prior art, such as different sizes of arc plates, different radian sizes, long time consumption of manual cutting and poor quality, the invention provides an automatic-guiding stone gap correction cutting method and device.
An automatic guiding stone gap correction cutting method; the method is characterized in that: the cutting method comprises the following steps;
s1; cleaning a to-be-repaired seam area, cleaning the peripheral position of a joint, then coating colorless fluorescent paint along the seam, and enclosing the area to avoid the interference of irrelevant personnel in operation;
s2; positioning identification piles are arranged every 10m at a position which is about 1m away from the vertical gap along the gap repairing path, auxiliary positioning is carried out on the gap repairing device, meanwhile, a starting point control groove is pasted at a proper position on the ground where the device starts to work, and the opening of the groove faces to the position of the running direction of the gap repairing device;
s3; opening a power supply of the seam repairing device, adjusting to a path planning mode, lifting a blade at the moment, and continuously emitting ultraviolet rays by two groups of identification mechanisms positioned at the front part and the middle and rear part of the device; the device is arranged at a working starting point, so that the lower starting point pile is just positioned in the starting point control groove, and then the device is started and driven by a motor to advance;
s4; the ultraviolet rays enable the coated fluorescent agent to react to emit fluorescent light, the camera device positioned in the recognition device intelligently draws a working surface on the simulator according to the returned light sensation data, and simultaneously transmits the data to the guide mechanism to control the front wheel to turn, so that the position of the cutter opening of the original cutting disc is aligned to the center of the gap; during the advancing process, the positioning identification pile and an identification mechanism in the device perform radar wave positioning, the traveling position of the device is recorded, data are input into an intelligent processor to process, analyze and display a traveling path, a gap position and a cutting edge path of the device, and an operator can modify and confirm the path through intelligent equipment;
s5, after data processing is finished, transmitting the data to a seam repairing device, adjusting the data to a cutting mode, enabling a blade to descend to a position close to the ground, then placing the seam repairing device at a working starting point, enabling a starting point pile below the seam repairing device to be just positioned in a starting point control groove, and then starting the device;
s6; the ultraviolet emission and fluorescence identification camera device works as usual, the device continuously advances by combining route information guided by the system, positioning identification pile positioning information and adjusting the cutting blade to move up and down, left and right and rotate, and the gap fine trimming is carried out by matching with the real-time monitoring of the identification device and the position control of the guide mechanism;
s7; repeating the steps until all the gaps are corrected, wherein a new starting point control groove needs to be arranged on the cutting seam of each gap, and the positioning identification pile and the starting point control groove cannot move in the gap repairing process;
s8; after all the seam repairing operations are removed, cleaning the working area by adopting alcohol or acetone, and removing the fluorescent agent.
Preferably, the seam repairing device comprises a movable frame, a power assembly, a steering assembly, a fixed frame, a first radar wave transceiver, a second radar wave transceiver, a starting point base, a starting point control groove, a starting point pile and a cutting assembly; a power assembly and a steering assembly are arranged in the moving frame; a fixed frame is fixedly connected in the movable frame; a plurality of first radar wave transceivers are fixedly connected in the fixed frame; a plurality of starting point piles are fixedly connected to the lower surface of the moving frame; the starting pile is buckled and connected in the starting control groove; the starting point control groove is formed in the starting point base; a plurality of second radar wave transceivers are fixedly connected inside the starting point base; and a cutting assembly is arranged in the moving vehicle frame.
Preferably, the cutting assembly comprises a working through groove, a supporting frame, an angle adjusting groove, a sliding block, a first motor, a threaded shaft, a threaded sleeve, a first supporting shaft, a second motor, a motor fixing disc, a cutting blade, a buckling base, a sliding shaft, an elastic piece and a rotator; a working through groove is formed in the movable frame; a supporting frame is fixedly connected to the edge of the working through groove; an angle adjusting groove is formed in the movable frame around the supporting frame; a plurality of sliding blocks are buckled and slidably connected inside the angle adjusting groove; a plurality of first motors are fixedly connected to the sliding block; the output end of the first motor is fixedly connected with a threaded shaft; a threaded sleeve is sleeved on the threaded shaft in a threaded manner; the threaded sleeve is rotatably connected to the first support shaft and the second support shaft; a motor fixing disc is fixedly connected to the opening of the second supporting shaft; a second motor is detachably and fixedly connected to the motor fixing disc; the output end of the second motor is fixedly connected with a cutting blade; the output end of the second motor is inserted on the buckling base; the buckling base is rotatably connected in the first supporting shaft; a sliding shaft is fixedly connected to the side surface of the buckling base; the sliding shaft is sleeved with an elastic piece; a rotator is fixedly connected to the second supporting shaft; a third motor is fixedly connected to the rotator; the third motor is fixedly connected inside the motor protective cover; the motor protective cover is fixedly connected to the movable frame.
Preferably, the power assembly consists of a motor, a speed reducer and a gear; the angle adjusting groove is in a quarter shape of a circular ring.
Preferably, a plurality of irradiation mounting boxes are fixedly connected to the opening of the moving frame; a plurality of cameras, ultraviolet emitters and processors are fixedly connected inside the irradiation mounting box.
Preferably, an intelligent module and a battery are arranged inside the movable frame; the battery and the intelligent module.
Preferably, two anti-collision sensors are fixedly connected to two ends of the front side of the moving frame, and the sensors act to cause the cutting assembly to be powered off.
The application has the advantages that:
1. according to the invention, through the structural design of the movable frame, the power assembly, the steering assembly, the fixed frame, the first radar wave transceiver, the second radar wave transceiver, the starting point base, the starting point control groove, the starting point pile, the processor, the first motor, the second motor and the cutting blade, the function of quick, efficient and accurate gap correction is realized, the problem of low efficiency of traditional manual gap repair is solved, and the gap repair efficiency is improved;
2. according to the invention, through the structural design of the irradiation safety box, the camera, the ultraviolet emitter, the processor, the first motor, the second motor, the cutting blade and the rotator, the functions of automatic seam repair and automatic angle adjustment are realized, the problems of time and labor waste, high cost and uneven technology of the traditional manual seam repair device are solved, the compatibility of the seam repair device is improved, and the seam repair cost is reduced.
Drawings
In order to more clearly illustrate the embodiments of the present application or the technical solutions in the prior art, the drawings needed to be used in the description of the embodiments or the prior art will be briefly introduced below, and it is obvious that the drawings in the following description are only some embodiments of the present application, and it is obvious for those skilled in the art that other drawings can be obtained according to the drawings without inventive exercise.
FIG. 1 is a schematic flow chart of a method according to an embodiment of the present application;
FIG. 2 is a schematic external structural view of an embodiment of the present application;
FIG. 3 is a schematic top cross-sectional view of an embodiment of the present application;
FIG. 4 is a schematic top view of an embodiment of the present application;
FIG. 5 is a schematic diagram of a front view of an embodiment of the present application;
fig. 6 is an enlarged schematic structural diagram at a in fig. 3 according to an embodiment of the present application.
In the figure: 1. moving the frame; 2. a power assembly; 3. a steering assembly; 4. a fixing frame; 5. a first radar wave transceiver; 6. a second radar wave transceiver; 7. a starting point base; 8. a starting point control slot; 9. starting piles; 10. irradiating the mounting box; 11. a camera; 12. an ultraviolet emitter; 13. a processor; 14. a working through groove; 15. supporting the frame; 16. an angle adjusting groove; 17. a slider; 18. a first motor; 19. a threaded shaft; 20. a threaded bushing; 21. a first support shaft; 22. a second support shaft; 23. a second motor; 24. a motor fixing disc; 25. a cutting blade; 26. buckling the base; 27. a sliding shaft; 28. an elastic member; 29. a rotator; 30. an intelligent module; 31. a battery; 32. a motor protection cover; 33. an electric motor.
Detailed Description
The technical solutions in the embodiments of the present invention will be clearly and completely described below with reference to the drawings in the embodiments of the present invention, and it is obvious that the described embodiments are only a part of the embodiments of the present invention, and not all of the embodiments. All other embodiments, which can be obtained by a person skilled in the art without inventive step based on the embodiments of the present invention, are within the scope of the present invention
Referring to fig. 1-6, a method for automatically guiding stone gap correction cutting; the method is characterized in that: the cutting method comprises the following steps;
s1; cleaning a to-be-repaired seam area, cleaning the peripheral position of a joint, then coating colorless fluorescent paint along the seam, and enclosing the area to avoid the interference of irrelevant personnel in operation;
s2; positioning identification piles are arranged every 10m at a position which is about 1m away from the vertical gap along the gap repairing path, auxiliary positioning is carried out on the gap repairing device, meanwhile, a starting point control groove is pasted at a proper position on the ground where the device starts to work, and the opening of the groove faces to the position of the running direction of the gap repairing device;
s3; opening a power supply of the seam repairing device, adjusting to a path planning mode, lifting a blade at the moment, and continuously emitting ultraviolet rays by two groups of identification mechanisms positioned at the front part and the middle and rear part of the device; the device is arranged at a working starting point, so that the lower starting point pile is just positioned in the starting point control groove, and then the device is started and driven by a motor to advance;
s4; the ultraviolet rays enable the coated fluorescent agent to react to emit fluorescent light, the camera device positioned in the recognition device intelligently draws a working surface on the simulator according to the returned light sensation data, and simultaneously transmits the data to the guide mechanism to control the front wheel to turn, so that the position of the cutter opening of the original cutting disc is aligned to the center of the gap; during the advancing process, the positioning identification pile and an identification mechanism in the device perform radar wave positioning, the traveling position of the device is recorded, data are input into an intelligent processor to process, analyze and display a traveling path, a gap position and a cutting edge path of the device, and an operator can modify and confirm the path through intelligent equipment;
s5, after data processing is finished, transmitting the data to a seam repairing device, adjusting the data to a cutting mode, enabling a blade to descend to a position close to the ground, then placing the seam repairing device at a working starting point, enabling a starting point pile below the seam repairing device to be just positioned in a starting point control groove, and then starting the device;
s6; the ultraviolet emission and fluorescence identification camera device works as usual, the device continuously advances by combining route information guided by the system, positioning identification pile positioning information and adjusting the cutting blade to move up and down, left and right and rotate, and the gap fine trimming is carried out by matching with the real-time monitoring of the identification device and the position control of the guide mechanism;
s7; repeating the steps until all the gaps are corrected, wherein a new starting point control groove needs to be arranged on the cutting seam of each gap, and the positioning identification pile and the starting point control groove cannot move in the gap repairing process;
s8; after all the seam repairing operations are removed, cleaning the working area by adopting alcohol or acetone, and removing the fluorescent agent.
The seam repairing device comprises a movable frame 1, a power assembly 2, a steering assembly 3, a fixed frame 4, a first radar wave transceiver 5, a second radar wave transceiver 6, a starting point base 7, a starting point control groove 8, a starting point pile 9 and a cutting assembly; a power assembly 2 and a steering assembly 3 are arranged in the moving frame 1; a fixed frame 4 is fixedly connected in the movable frame 1; a plurality of first radar wave transceivers 5 are fixedly connected in the fixed frame 4; a plurality of starting point piles 9 are fixedly connected to the lower surface of the moving frame 1; the starting pile 9 is buckled and connected in the starting control groove 8; the starting point control groove 8 is formed in the starting point base 7; a plurality of second radar wave transceivers 6 are fixedly connected inside the starting point base 7; a cutting assembly is arranged in the moving vehicle frame 1.
The cutting assembly comprises a working through groove 14, a supporting frame 15, an angle adjusting groove 16, a sliding block 17, a first motor 18, a threaded shaft 19, a threaded sleeve 20, a first supporting shaft 21, a second supporting shaft 22, a second motor 23, a motor fixing disc 24, a cutting blade 25, a buckling base 26, a sliding shaft 27, an elastic piece 28 and a rotator 29; a working through groove 14 is formed in the movable frame 1; a supporting frame 15 is fixedly connected to the edge of the working through groove 14; an angle adjusting groove 16 is formed in the movable frame 1 around the supporting frame 15; a plurality of sliding blocks 17 are buckled and slidably connected inside the angle adjusting groove 16; a plurality of first motors 18 are fixedly connected to the sliding block 17; the output end of the first motor 18 is fixedly connected with a threaded shaft 19; a threaded sleeve 20 is sleeved on the threaded shaft 19 in a threaded manner; the threaded sleeve 20 is rotatably connected to a first support shaft 21 and a second support shaft 22; a motor fixing disc 24 is fixedly connected to the opening of the second supporting shaft 22; the motor fixing disc 24 is detachably and fixedly connected with a second motor 23; a cutting blade 25 is fixedly connected to the output end of the second motor 23; the output end of the second motor 23 is inserted on the buckling base 26; the buckling base 26 is rotatably connected in the first supporting shaft 21; a sliding shaft 27 is fixedly connected to the side surface of the buckling base 26; the sliding shaft 27 is sleeved with an elastic piece 28; a rotator 29 is fixedly connected to the second supporting shaft 22; a third motor 33 is fixedly connected to the rotator 29; the third motor 33 is fixedly connected inside the motor protective cover 32; the motor protective cover 32 is fixedly connected to the movable frame 1; the power assembly 2 consists of a motor, a speed reducer and a gear; the angle adjusting groove 16 is in a quarter shape of a circular ring; a plurality of irradiation mounting boxes 10 are fixedly connected to the opening of the moving frame 1; a plurality of cameras 11, ultraviolet emitters 12 and processors 13 are fixedly connected inside the irradiation mounting box 10; an intelligent module 30 and a battery 31 are arranged inside the moving frame 1; the battery 31 and the intelligent module 30; two anti-collision sensors are fixedly connected to two ends of the front side of the moving frame 1, and the sensors act to cause the cutting assembly to be powered off.
According to the working principle, the power assembly 2 and the steering assembly 3 are arranged in the movable frame 1, the power assembly 2 consists of a motor, a speed reducer, a gear, a roller and a connecting shaft, and the steering assembly 3 consists of a motor, a double-arm connecting rod and a roller; through the design, the device can realize the accurate real-time positioning of the mobile frame 1 through the alternating positioning of the first radar wave transceiver 5 and the second radar wave transceiver 6; through the design that two irradiation mounting boxes 10 are obliquely and fixedly connected with a front side opening and a bottom side opening of the moving frame 1, a plurality of cameras 11, ultraviolet emitters 12 and a processor 13 are fixedly connected inside the irradiation mounting boxes 10, the device can irradiate and change color of fluorescent agent solution in a ground gap through the ultraviolet emitters 12, and perform optical identification through the cameras 11, so that the device can accurately walk along a route, positioning identification piles are placed at one meter positions on the side surfaces of the gap, radar wave transceivers are placed inside the positioning identification piles, and the traveling positions are accurately recorded in interaction among the first radar wave emitter 5, the second radar wave emitter 6 and the plurality of radar wave positioning piles; a working through groove 14 is formed in the lower surface of a moving vehicle frame 1, a supporting frame 15 is fixedly connected to the edge of the working through groove 14, a circular part of angle adjusting groove 15 is formed in the moving vehicle frame 1 around the supporting frame 15, two sliding blocks 17 are connected to the inside of the angle adjusting groove 15 in a buckling and sliding mode, a first motor 18 is fixedly connected to each sliding block 17, a threaded shaft 19 is fixedly connected to the output end of each first motor 18, the threaded shaft 19 is connected to a threaded sleeve 20 in a threaded mode, the two threaded sleeves 20 are rotatably connected to a first supporting shaft 21 and a second supporting shaft 22, the first supporting shaft 21 and the second supporting shaft 22 are connected to the supporting frame 15 in a buckling and sliding mode, a motor fixing disc 24 is fixedly connected to an opening in the second supporting shaft 22, a second motor 23 is fixedly connected to the inside opening of the motor fixing disc 24, a cutting blade 25 is fixedly connected to the output end of the second motor 23, the buckling base 26 is buckled and rotatably connected on the first supporting shaft 21, a sliding shaft 27 is fixedly connected on the buckling base 26, an elastic part 28 is sleeved on the sliding shaft 27, the sliding shaft 27 is rotatably connected on the first supporting shaft 21, a rotator 29 is fixedly connected on the second supporting shaft 22, a third motor 33 is fixedly connected on the rotator 29, the third motor 33 is fixedly connected in a motor protective cover 32, the motor protective cover 32 is fixedly connected on the moving frame 1, through the design, the buckling base 26 in the device can rotate along with the cutting blade 25, the cutting blade 25 is symmetrically supported and protected, the first supporting shaft 21 and the second supporting shaft 22 can be controlled to ascend and descend by matching the two first motors 18, the threaded shaft 19 and the threaded sleeve 20, gaps with different depths are matched, the angle of the cutting blade 25 can be circumferentially adjusted under the action of the rotator 29, the angle adjusting groove 16 and the sliding block 17, thereby adapting to different gaps; through the inside rigid coupling that has intelligent object 30 and battery 31 at moving vehicle frame 1, intelligent object 30 comprises recognizer, controller, treater, signal transmission unit, battery 31 and intelligent object 30, first motor 18, second motor 23, first radar wave transceiver 5 and second radar wave transceiver 6 electric connection, through such design for this device can practice each components and parts of electronic control and control.
Since the structures of the power assembly 2, the steering assembly 3 and the intelligent module 30 belong to the prior art, they are not described in the present document.
In the description herein, references to the description of "one embodiment," "an example," "a specific example" or the like are intended to mean that a particular feature, structure, material, or characteristic described in connection with the embodiment or example is included in at least one embodiment or example of the invention. In this specification, the schematic representations of the terms used above do not necessarily refer to the same embodiment or example. Furthermore, the particular features, structures, materials, or characteristics described may be combined in any suitable manner in any one or more embodiments or examples.
The foregoing shows and describes the general principles, essential features, and advantages of the invention. It will be understood by those skilled in the art that the present invention is not limited to the embodiments described above, which are described in the specification and illustrated only to illustrate the principle of the present invention, but that various changes and modifications may be made therein without departing from the spirit and scope of the present invention, which fall within the scope of the invention as claimed.
Claims (7)
1. An automatic guiding stone gap correction cutting method; the method is characterized in that: the cutting method comprises the following steps;
s1; cleaning a to-be-repaired seam area, cleaning the peripheral position of a joint, then coating colorless fluorescent paint along the seam, and enclosing the area to avoid the interference of irrelevant personnel in operation;
s2; positioning identification piles are arranged every 10m at a position which is about 1m away from the vertical gap along the gap repairing path, auxiliary positioning is carried out on the gap repairing device, meanwhile, a starting point control groove is pasted at a proper position on the ground where the device starts to work, and the opening of the groove faces to the position of the running direction of the gap repairing device;
s3; opening a power supply of the seam repairing device, adjusting to a path planning mode, lifting a blade at the moment, and continuously emitting ultraviolet rays by two groups of identification mechanisms positioned at the front part and the middle and rear part of the device; the device is arranged at a working starting point, so that the lower starting point pile is just positioned in the starting point control groove, and then the device is started and driven by a motor to advance;
s4; the ultraviolet rays enable the coated fluorescent agent to react to emit fluorescent light, the camera device positioned in the recognition device intelligently draws a working surface on the simulator according to the returned light sensation data, and simultaneously transmits the data to the guide mechanism to control the front wheel to turn, so that the position of the cutter opening of the original cutting disc is aligned to the center of the gap; during the advancing process, the positioning identification pile and an identification mechanism in the device perform radar wave positioning, the traveling position of the device is recorded, data are input into an intelligent processor to process, analyze and display a traveling path, a gap position and a cutting edge path of the device, and an operator can modify and confirm the path through intelligent equipment;
s5, after data processing is finished, transmitting the data to a seam repairing device, adjusting the data to a cutting mode, enabling a blade to descend to a position close to the ground, then placing the seam repairing device at a working starting point, enabling a starting point pile below the seam repairing device to be just positioned in a starting point control groove, and then starting the device;
s6; the ultraviolet emission and fluorescence identification camera device works as usual, the device continuously advances by combining route information guided by the system, positioning identification pile positioning information and adjusting the cutting blade to move up and down, left and right and rotate, and the gap fine trimming is carried out by matching with the real-time monitoring of the identification device and the position control of the guide mechanism;
s7; repeating the steps until all the gaps are corrected, wherein a new starting point control groove needs to be arranged on the cutting seam of each gap, and the positioning identification pile and the starting point control groove cannot move in the gap repairing process;
s8; after all the seam repairing operations are removed, cleaning the working area by adopting alcohol or acetone, and removing the fluorescent agent.
2. The apparatus of claim 1, wherein the cutting device comprises: the seam repairing device comprises a movable frame (1), a power assembly (2), a steering assembly (3), a fixed frame (4), a first radar wave transceiver (5), a second radar wave transceiver (6), a starting point base (7), a starting point control groove (8), a starting point pile (9) and a cutting assembly; a power assembly (2) and a steering assembly (3) are arranged in the moving frame (1); a fixed frame (4) is fixedly connected in the movable frame (1); a plurality of first radar wave transceivers (5) are fixedly connected in the fixed frame (4); a plurality of starting point piles (9) are fixedly connected to the lower surface of the moving frame (1); the starting pile (9) is buckled and connected in the starting control groove (8); the starting point control groove (8) is arranged in the starting point base (7); a plurality of second radar wave transceivers (6) are fixedly connected inside the starting point base (7); a cutting assembly is arranged in the moving vehicle frame (1).
3. The apparatus of claim 2, wherein the cutting device comprises: the cutting assembly comprises a working through groove (14), a supporting frame (15), an angle adjusting groove (16), a sliding block (17), a first motor (18), a threaded shaft (19), a threaded sleeve (20), a first supporting shaft (21), a second supporting shaft (22), a second motor (23), a motor fixing disc (24), a cutting blade (25), a buckling base (26), a sliding shaft (27), an elastic piece (28) and a rotator (29); a working through groove (14) is formed in the movable frame (1); a supporting frame (15) is fixedly connected to the edge of the working through groove (14); an angle adjusting groove (16) is formed in the movable frame (1) around the supporting frame (15); a plurality of sliding blocks (17) are buckled and slidably connected inside the angle adjusting groove (16); a plurality of first motors (18) are fixedly connected to the sliding block (17); the output end of the first motor (18) is fixedly connected with a threaded shaft (19); a threaded sleeve (20) is sleeved on the threaded shaft (19) in a threaded manner; the threaded sleeve (20) is rotatably connected to the first support shaft (21) and the second support shaft (22); a motor fixing disc (24) is fixedly connected to the opening of the second supporting shaft (22); a second motor (23) is detachably and fixedly connected to the motor fixing disc (24); the output end of the second motor (23) is fixedly connected with a cutting blade (25); the output end of the second motor (23) is inserted on the buckling base (26); the buckling base (26) is rotatably connected in the first supporting shaft (21); a sliding shaft (27) is fixedly connected to the side surface of the buckling base (26); an elastic piece (28) is sleeved on the sliding shaft (27); a rotator (29) is fixedly connected to the second support shaft (22); a third motor (33) is fixedly connected to the rotator (29); the third motor (33) is fixedly connected inside the motor protective cover (32); the motor protective cover (32) is fixedly connected to the movable frame (1).
4. The apparatus of claim 3, wherein the cutting device comprises: the power assembly (2) consists of a motor, a speed reducer and a gear; the angle adjusting groove (16) is in a quarter shape of a circular ring.
5. The apparatus of claim 4, wherein the cutting device comprises: a plurality of irradiation mounting boxes (10) are fixedly connected to the opening of the movable frame (1); the irradiation mounting box (10) is fixedly connected with a plurality of cameras (11), an ultraviolet emitter (12) and a processor (13).
6. The apparatus of claim 5, wherein the cutting device comprises: an intelligent module (30) and a battery (31) are arranged in the movable frame (1); the battery (31) and the intelligent module (30).
7. The apparatus of claim 6, wherein the cutting device comprises: two anti-collision sensors are fixedly connected to two ends of the front side of the moving vehicle frame (1), and the sensors act to cause the cutting assembly to be powered off.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202011436808.6A CN112590026B (en) | 2020-12-07 | 2020-12-07 | Automatic-guiding stone gap correction cutting method and device thereof |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202011436808.6A CN112590026B (en) | 2020-12-07 | 2020-12-07 | Automatic-guiding stone gap correction cutting method and device thereof |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN112590026A true CN112590026A (en) | 2021-04-02 |
| CN112590026B CN112590026B (en) | 2022-09-16 |
Family
ID=75191556
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202011436808.6A Active CN112590026B (en) | 2020-12-07 | 2020-12-07 | Automatic-guiding stone gap correction cutting method and device thereof |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN112590026B (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113183296A (en) * | 2021-05-06 | 2021-07-30 | 福建厚德节能科技发展有限公司 | Preparation method and cutting device of autoclaved aerated concrete |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN201280684Y (en) * | 2008-10-20 | 2009-07-29 | 朱永山 | Self-propelled seam repairing machine for airport runway |
| JP2010174520A (en) * | 2009-01-29 | 2010-08-12 | Hitachi Koki Co Ltd | Engine cutter, engine cutter with wheels, and cutting method |
| CN107806001A (en) * | 2017-11-07 | 2018-03-16 | 汤庆佳 | A kind of road rehabilitation system based on two-dimensional coordinate processing |
| CN108103911A (en) * | 2017-12-01 | 2018-06-01 | 顾瑜均 | A kind of pavement cutting machine equipped with flyrock protection mechanism for road construction |
| JP2018193726A (en) * | 2017-05-15 | 2018-12-06 | 株式会社極東体育施設 | Cutting device for laying or paving material and cutting method therefor |
| CN108951394A (en) * | 2018-08-02 | 2018-12-07 | 安徽永生堂药业有限责任公司 | A kind of municipal construction joint cutter |
| CN111593645A (en) * | 2020-05-25 | 2020-08-28 | 安徽文天信息科技有限公司 | A pavement slitting device with adjustable slitting depth for concrete highway construction |
-
2020
- 2020-12-07 CN CN202011436808.6A patent/CN112590026B/en active Active
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN201280684Y (en) * | 2008-10-20 | 2009-07-29 | 朱永山 | Self-propelled seam repairing machine for airport runway |
| JP2010174520A (en) * | 2009-01-29 | 2010-08-12 | Hitachi Koki Co Ltd | Engine cutter, engine cutter with wheels, and cutting method |
| JP2018193726A (en) * | 2017-05-15 | 2018-12-06 | 株式会社極東体育施設 | Cutting device for laying or paving material and cutting method therefor |
| CN107806001A (en) * | 2017-11-07 | 2018-03-16 | 汤庆佳 | A kind of road rehabilitation system based on two-dimensional coordinate processing |
| CN108103911A (en) * | 2017-12-01 | 2018-06-01 | 顾瑜均 | A kind of pavement cutting machine equipped with flyrock protection mechanism for road construction |
| CN108951394A (en) * | 2018-08-02 | 2018-12-07 | 安徽永生堂药业有限责任公司 | A kind of municipal construction joint cutter |
| CN111593645A (en) * | 2020-05-25 | 2020-08-28 | 安徽文天信息科技有限公司 | A pavement slitting device with adjustable slitting depth for concrete highway construction |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113183296A (en) * | 2021-05-06 | 2021-07-30 | 福建厚德节能科技发展有限公司 | Preparation method and cutting device of autoclaved aerated concrete |
Also Published As
| Publication number | Publication date |
|---|---|
| CN112590026B (en) | 2022-09-16 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN103978414B (en) | The automatic kibbling mill of arc plate | |
| RU2005138027A (en) | LABELING OF LARGE SURFACES WITH VISUAL REPRESENTATIONS | |
| CN112590026B (en) | Automatic-guiding stone gap correction cutting method and device thereof | |
| CN110568448B (en) | Device and method for identifying accumulated slag at bottom of tunnel of hard rock tunnel boring machine | |
| CN103817727B (en) | Rubber stripping machine | |
| CN110406308A (en) | A kind of wall paper spreading robot and its method of adjustment, wall paper spreading method | |
| KR101501887B1 (en) | Vehicle film cutting device and cutting method thereof | |
| CN104401136A (en) | Laser marking device for stainless steel and method | |
| CN117604846B (en) | Pavement crack non-color difference intelligent repair system and method based on image recognition | |
| CN220079692U (en) | Automatic gauge length marking machine special for highway | |
| CN109183597A (en) | A kind of highway engineering construction zebra stripes lineation device | |
| CN206425685U (en) | The laser process equipment of cell phone rear cover and frame | |
| CN211640532U (en) | Intelligent stone cutting machine with double working platforms and walking beams | |
| CN206983001U (en) | A kind of multi-functional full-automatic groover | |
| CN101961716A (en) | Ring-die intelligent automatic cleaning plant | |
| CN108818207A (en) | A kind of four side continuous edge grinding machine group of glass | |
| CN203792393U (en) | Rubber stripping and cutting machine | |
| CN110983939A (en) | road marking machine | |
| CN201321686Y (en) | Serial production line for machining polyurethane sheet with lap joint | |
| CN218132962U (en) | Automatic optical alignment dispensing machine | |
| CN115233526B (en) | Rail type airport pavement cutting operation machine and precise cutting method for cutting seams | |
| CN202114982U (en) | Chamfering and edge folding equipment for full-paper packaging barrel | |
| CN110370857A (en) | A kind of laser cutting device and wall paper spreading device | |
| CN105619578A (en) | Automatic concrete chiseling equipment of prefabricated bridge hollow slab web and construction method | |
| CN205152768U (en) | Straight line highway cutting machine |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |