CN112363537B - Unmanned aerial vehicle parking apron monitoring method, cloud platform server and storage medium - Google Patents
Unmanned aerial vehicle parking apron monitoring method, cloud platform server and storage medium Download PDFInfo
- Publication number
- CN112363537B CN112363537B CN202011632645.9A CN202011632645A CN112363537B CN 112363537 B CN112363537 B CN 112363537B CN 202011632645 A CN202011632645 A CN 202011632645A CN 112363537 B CN112363537 B CN 112363537B
- Authority
- CN
- China
- Prior art keywords
- target
- street lamp
- lamp post
- aerial vehicle
- unmanned aerial
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 238000012544 monitoring process Methods 0.000 title claims abstract description 88
- 238000000034 method Methods 0.000 title claims abstract description 46
- 230000008569 process Effects 0.000 claims abstract description 13
- 238000007689 inspection Methods 0.000 claims abstract description 4
- 230000007613 environmental effect Effects 0.000 claims description 84
- 238000012806 monitoring device Methods 0.000 claims description 37
- 238000004590 computer program Methods 0.000 claims description 5
- 238000005516 engineering process Methods 0.000 abstract description 8
- 230000005540 biological transmission Effects 0.000 description 3
- 238000004891 communication Methods 0.000 description 3
- 230000003993 interaction Effects 0.000 description 2
- 238000012986 modification Methods 0.000 description 2
- 230000004048 modification Effects 0.000 description 2
- 238000012545 processing Methods 0.000 description 2
- 230000009286 beneficial effect Effects 0.000 description 1
- 238000011161 development Methods 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 230000006870 function Effects 0.000 description 1
- 230000006872 improvement Effects 0.000 description 1
- 230000006698 induction Effects 0.000 description 1
- 238000010606 normalization Methods 0.000 description 1
- 238000011160 research Methods 0.000 description 1
- 230000000717 retained effect Effects 0.000 description 1
Images

Classifications
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/10—Simultaneous control of position or course in three dimensions
- G05D1/101—Simultaneous control of position or course in three dimensions specially adapted for aircraft
Landscapes
- Engineering & Computer Science (AREA)
- Aviation & Aerospace Engineering (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Traffic Control Systems (AREA)
Abstract
The invention relates to the technical field of unmanned aerial vehicle monitoring, in particular to an unmanned aerial vehicle parking apron monitoring method, a cloud platform server and a storage medium. Firstly, generating target flight track information of a target unmanned aerial vehicle according to preset conditions, wherein the target flight track information comprises track information of each target street lamp pole which is required to pass through by the target unmanned aerial vehicle for one-time flight inspection, the target street lamp pole is at least one of a plurality of street lamps, the plurality of street lamp poles form a ring shape, and any three adjacent street lamp poles are not on the same straight line; secondly, sending the target flight track information to a target unmanned aerial vehicle; and then, acquiring a monitoring picture shot by the target unmanned aerial vehicle in the process of flying to each target street lamp pole to obtain at least one monitoring picture. Based on the method, the problem that the existing unmanned aerial vehicle monitoring technology is unreasonable in monitoring can be solved.
Description
Technical Field
The invention relates to the technical field of unmanned aerial vehicle monitoring, in particular to an unmanned aerial vehicle parking apron monitoring method, a cloud platform server and a storage medium.
Background
Along with the continuous development of unmanned aerial vehicle monitoring technology, its range of application is constantly expanded. For example, in the prior art, in order to provide a convenient charging and parking environment, the unmanned aerial vehicle monitoring technology is combined with the existing street lamp, so that the charging device arranged on the street lamp pole can be used for charging, and the parking apron arranged on the street lamp pole is used for parking, such as rainy days.
The inventor researches and discovers that although reliable charging and parking of the unmanned aerial vehicle can be guaranteed in the existing unmanned aerial vehicle monitoring technology, the problem of unreasonable monitoring exists.
Disclosure of Invention
In view of the above, the present invention provides a method for monitoring an unmanned aerial vehicle apron, a cloud platform server and a storage medium, so as to solve the problem of unreasonable monitoring in the existing unmanned aerial vehicle monitoring technology.
In order to achieve the above purpose, the embodiment of the invention adopts the following technical scheme:
in a first aspect, the invention provides a method for monitoring an unmanned aerial vehicle parking apron, which is applied to a cloud platform server, wherein the cloud platform server is arranged on one of a plurality of street lamp poles, and each street lamp pole is respectively provided with the parking apron for parking the unmanned aerial vehicle, and the method for monitoring the unmanned aerial vehicle parking apron comprises the following steps:
generating target flight track information of a target unmanned aerial vehicle according to preset conditions, wherein the target flight track information comprises track information of each target street lamp pole which is required to pass by the target unmanned aerial vehicle in sequence for one-time flight inspection, the target street lamp pole is at least one, the street lamp poles form a ring shape, and any three adjacent street lamp poles are not on the same straight line;
sending the target flight trajectory information to the target unmanned aerial vehicle, wherein the target unmanned aerial vehicle flies to each target street lamp pole in sequence based on the target flight trajectory information;
and acquiring a monitoring picture shot by the target unmanned aerial vehicle in the process of flying to each target street lamp pole to obtain at least one monitoring picture.
In a second aspect, the present invention provides a cloud platform server; the cloud platform server comprises a processor and a memory which are communicated with each other, and the processor calls the computer program in the memory and runs the computer program to realize the method of the first aspect.
In a third aspect, the present invention provides a computer-readable storage medium; the computer readable storage medium has stored therein instructions that, when executed, cause a computer to perform the method of the first aspect.
The technical scheme provided by the embodiment of the invention can have the following beneficial effects: the invention provides a method for forming target flight track information of a target unmanned aerial vehicle by selecting at least one target street lamp pole from a plurality of street lamp poles forming an annular shape, so that the flight track of the target unmanned aerial vehicle, namely, a patrol track can present an annular rule. So, can be so that target unmanned aerial vehicle's patrolling orbit is more reasonable to improve the reliability of control, and then improve the unreasonable problem of control that exists among the current unmanned aerial vehicle monitoring technology, make and have higher practical value.
In order to make the aforementioned and other objects, features and advantages of the present invention comprehensible, preferred embodiments accompanied with figures are described in detail below.
Drawings
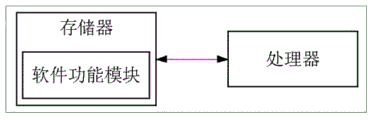
Fig. 1 is a block diagram of a cloud platform server according to an embodiment of the present invention.
Fig. 2 is a schematic flow chart of steps included in the method for monitoring an unmanned aerial vehicle apron in an embodiment of the present invention.
Detailed Description
In order to make the objects, technical solutions and advantages of the embodiments of the present invention clearer, the technical solutions in the embodiments of the present invention will be clearly and completely described below with reference to the drawings in the embodiments of the present invention, and it is obvious that the described embodiments are only a part of the embodiments of the present invention, and not all of the embodiments. The components of embodiments of the present invention generally described and illustrated in the figures herein may be arranged and designed in a wide variety of different configurations.
Thus, the following detailed description of the embodiments of the present invention, presented in the figures, is not intended to limit the scope of the invention, as claimed, but is merely representative of selected embodiments of the invention. All other embodiments, which can be derived by a person skilled in the art from the embodiments given herein without making any creative effort, shall fall within the protection scope of the present invention.
As shown in fig. 1, an embodiment of the present invention provides a cloud platform server. Wherein the cloud platform server may include a memory and a processor.
In detail, the memory and the processor are electrically connected directly or indirectly to realize data transmission or interaction. For example, they may be electrically connected to each other via one or more communication buses or signal lines. The memory may have stored therein at least one software function, which may be in the form of software or firmware. The processor may be configured to execute an executable computer program stored in the memory, such as the software functional module, so as to implement the method for monitoring an unmanned aerial vehicle apron provided by the embodiment of the present invention.
Alternatively, the Memory may be, but is not limited to, a Random Access Memory (RAM), a Read Only Memory (ROM), a Programmable Read-Only Memory (PROM), an Erasable Read-Only Memory (EPROM), an electrically Erasable Read-Only Memory (EEPROM), and the like.
Also, the Processor may be a general-purpose Processor including a Central Processing Unit (CPU), a Network Processor (NP), a System on Chip (SoC), and the like; but may also be a Digital Signal Processor (DSP), an Application Specific Integrated Circuit (ASIC), a Field Programmable Gate Array (FPGA) or other programmable logic device, discrete gate or transistor logic device, discrete hardware components.
The cloud platform server may be an electronic device having data processing capabilities.
Also, the structure shown in fig. 1 is only an illustration, and the cloud platform server may further include more or fewer components than those shown in fig. 1, or have a different configuration from that shown in fig. 1, for example, may further include a communication unit for information interaction with other devices.
With reference to fig. 2, an embodiment of the present invention further provides a method for monitoring an unmanned aerial vehicle parking apron, which is applicable to the cloud platform server. The method steps defined by the flow related to the unmanned aerial vehicle apron monitoring method can be realized by the cloud platform server.
And, the cloud platform server can set up in one in a plurality of street lamp poles, and is provided with the air park that is used for parking unmanned aerial vehicle on each street lamp pole respectively. The multiple street lamp poles can form a ring shape, and any three adjacent street lamp poles are not positioned on the same straight line.
The specific process shown in FIG. 2 will be described in detail below.
And step S110, generating target flight track information of the target unmanned aerial vehicle according to preset conditions.
In this embodiment, when the target drone needs to be controlled for patrol, the cloud platform server may generate target flight trajectory information of the target drone based on a preset condition.
The target flight track information comprises track information of each target street lamp pole which needs to pass through in sequence when the target unmanned aerial vehicle carries out primary flight patrol. And the target street lamp post is at least one, that is, the track information includes the position of at least one target street lamp post.
And step S120, sending the target flight path information to the target unmanned aerial vehicle.
In this embodiment, after generating the target flight trajectory information based on step S110, the cloud platform server may send the target flight trajectory information to the target drone.
After the target unmanned aerial vehicle acquires the target flight trajectory information, the target unmanned aerial vehicle can fly to each target street lamp pole in sequence based on the target flight trajectory information, so that one-time flight inspection can be completed, shooting is performed in the flying process, and a monitoring picture is formed.
Step S130, acquiring monitoring pictures shot by the target unmanned aerial vehicle in the process of flying to each target street lamp pole to obtain at least one monitoring picture.
In this embodiment, after the target flight trajectory information is sent to the target unmanned aerial vehicle based on step S120, the cloud platform server may obtain a monitoring picture shot by the target unmanned aerial vehicle in the process of flying to each target street light pole based on the target flight trajectory information, so that at least one monitoring picture may be obtained.
Based on the method, at least one target street lamp pole is selected from the plurality of street lamp poles forming the annular shape, and the target flight track information of the target unmanned aerial vehicle is formed, so that the flight track of the target unmanned aerial vehicle, namely the patrol track, can present an annular rule. So, can be so that target unmanned aerial vehicle's patrolling orbit is more reasonable (promptly the circulation patrols) to improve the reliability of control, and then improve the unreasonable problem of control that exists among the unmanned aerial vehicle monitoring technology now.
In the first aspect, it should be noted that, in step S110, a specific manner of generating the target flight trajectory information is not limited, and may be selected according to actual application requirements, and in this embodiment, based on different application requirements, the following four examples are provided respectively.
In a first example, step S110 may comprise sub-steps 10-20 in order to improve the stability of the target drone flight with a certain probability.
And a substep 10, sequentially forming a target street lamp post link (for example, a lamp post 1-a lamp post 2-a lamp post 3-a lamp post 4-a lamp post 5-a lamp post 1, which may form a ring shape, based on the adjacent relation between the street lamp posts, by using the street lamp post where the target unmanned aerial vehicle is currently located as a starting point and the street lamp post adjacent to the street lamp post as an end point, along a direction different from a direction having a minimum distance from the starting point to the end point, and by using the street lamp post adjacent to the starting point as the end point, making the formed target street lamp post link be the lamp post 2, the lamp post 3, the lamp post 4, the lamp post 5, or the lamp post 1.
And a substep 11, dividing the target street lamp post link to obtain a plurality of target street lamp post sublinks, wherein each target street lamp post sublink comprises a plurality of street lamp posts.
And a substep 12, regarding each two adjacent target street lamp post sublinks, using front and rear street lamp posts at the division positions of the two adjacent target street lamp post sublinks as reference street lamp posts (for example, combining the above example, two target street lamp post sublinks "lamp post 2, lamp post 3, lamp post 4" and "lamp post 5, lamp post 1" can be obtained, so that lamp post 4 and lamp post 5 can be used as two reference street lamp posts).
And a substep 13, for each two adjacent target street lamp post sublinks, allocating the reference street lamp post corresponding to the two adjacent target street lamp post sublinks to a previous target street lamp post sublink at a corresponding division position to obtain a first target street lamp post sublink, and taking a next target street lamp post sublink after allocation as a second target street lamp post sublink (for example, in combination with the above example, the first target street lamp post sublink is "lamp post 2, lamp post 3, lamp post 4, and lamp post 5", and the second target street lamp post sublink is "lamp post 1").
And a substep 14, for each two adjacent target street lamp post sublinks, allocating the reference street lamp post corresponding to the two adjacent target street lamp post sublinks to a next target street lamp post sublink at the corresponding division position to obtain a third target street lamp post sublink, and taking the allocated previous target street lamp post sublink as a fourth target street lamp post sublink (for example, in combination with the foregoing example, the third target street lamp post sublink is "lamp post 4, lamp post 5, lamp post 1", and the fourth target street lamp post sublink is "lamp post 2, lamp post 3").
Substep 15, for each two adjacent target street light pole sub-links, calculating a first environmental parameter mean value in a region range where a street light pole is located (for example, in combination with the above example, it is required to first obtain an environmental parameter in a region range where a light pole 2 is located, an environmental parameter in a region range where a light pole 3 is located, an environmental parameter in a region range where a light pole 4 is located, and an environmental parameter in a region range where a light pole 5 is located, and then calculate a mean value of 4 environmental parameters, where the environmental parameters may be wind speed or wind power, and the region range may be formed in advance, and the region ranges where two adjacent street light poles are located may be adjacent), and a second environmental parameter mean value in a region range where a street light pole is located included in the second target street light pole sub-link (for example, with reference to the foregoing example, it is necessary to first obtain the environmental parameters within the area range where the lamp post 1 is located, then calculate the mean value of the 1 environmental parameters), and calculate the difference between the first environmental parameter mean value and the second environmental parameter mean value to obtain a first difference value (i.e., subtracting the second environmental parameter mean value from the first environmental parameter mean value).
And a substep 16, for the third target street lamp post sublink and the fourth target street lamp post sublink corresponding to each two adjacent target street lamp post sublinks, calculating a third environmental parameter mean value in a region range where street lamp posts are located included in the third target street lamp post sublink and a fourth environmental parameter mean value in a region range where street lamp posts are located included in the fourth target street lamp post sublink, and calculating a difference between the third environmental parameter mean value and the fourth environmental parameter mean value to obtain a second difference value (refer to the above example).
In the substep 17, for each two adjacent target street lamp post sublinks, a fifth environmental parameter mean value in a region range where a street lamp post included in a previous target street lamp post sublink of the two adjacent target street lamp post sublinks is located and a sixth environmental parameter mean value in a region range where a street lamp post included in a next target street lamp post sublink is located are calculated, and a difference between the fifth environmental parameter mean value and the sixth environmental parameter mean value is calculated to obtain a third difference value (refer to the above example).
And substep 18, regarding each two adjacent target street lamp post sublinks, taking a difference value with a minimum value among the first difference value, the second difference value and the third difference value corresponding to the two adjacent target street lamp post sublinks as a target difference value of the two adjacent target street lamp post sublinks.
And a substep 19, determining, for each target difference value of two adjacent target street lamp post sublinks, one street lamp post from the street lamp posts included in the previous target street lamp post sublink of the two target street lamp post sublinks corresponding to the target difference value, as the target street lamp post corresponding to the target difference value (for example, in combination with the above example, if the first difference value is the smallest, one street lamp post can be determined from the first target street lamp post sublinks "lamp post 2, lamp post 3, lamp post 4, and lamp post 5" as the target street lamp post, if the last street lamp post, that is, lamp post 5, is used as the target street lamp post, it is ensured that the environment is relatively stable in the process that the target unmanned aerial vehicle flies to the next target street lamp post each time at a certain probability).
And a substep 20 of generating target flight trajectory information of the target drone based on the obtained target street light pole (for example, in connection with the foregoing example, the target flight trajectory information includes the light pole 5).
In a second example, in order to improve the stability of the flight of the target drone with a certain probability, step S110 may comprise sub-steps 21-30.
And a substep 21 of sequentially forming a target street lamp post link based on the adjacent relationship between the street lamp posts along a direction different from a direction having a minimum distance from the starting point to the end point, with the street lamp post where the target unmanned aerial vehicle is currently located as the starting point and the street lamp post adjacent to the street lamp post as the end point.
And a substep 22 of dividing the target street light pole link to obtain a plurality of target street light pole sub-links, wherein each target street light pole sub-link comprises a plurality of street light poles.
And a substep 23, for each target street lamp post sublink, obtaining the number of lamp posts of the street lamp posts included in the target street lamp post sublink (for example, for two target street lamp post sublinks, "lamp post 2, lamp post 3, lamp post 4" and "lamp post 5, lamp post 1", the corresponding number of lamp posts is 3 and 2, respectively).
And a substep 24, obtaining, for each target street lamp post sublink, an average value of the environmental parameters in the area range of the street lamp post included in the target street lamp post sublink (for example, in combination with the above example, for the target street lamp post sublink of "lamp post 2, lamp post 3, and lamp post 4", the environmental parameter in the area range of the lamp post 2, the environmental parameter in the area range of the lamp post 3, and the environmental parameter in the area range of the lamp post 4 need to be obtained first, and then the average values of the 3 environmental parameters are calculated to obtain the corresponding average values of the environmental parameters, so that for a plurality of target street lamp post sublinks, a plurality of average values of the environmental parameters can be obtained).
And a substep 25, determining a weighted sum value of the average values of the corresponding environmental parameters based on the number of the lamp posts corresponding to each target street lamp post sublink (namely, determining the weight coefficient of each target street lamp post sublink based on the number of the lamp posts of each target street lamp post sublink to obtain a plurality of weight parameters, and then performing weighted sum on the obtained plurality of average values of the environmental parameters to obtain a weighted sum value, wherein the larger the number of the lamp posts is, the larger the corresponding weight coefficient is).
And a substep 26 of determining whether the weighted sum is greater than a preset average.
And a substep 27, if the weighted sum is greater than or equal to the preset average, generating target flight trajectory information only including the street lamp post where the target unmanned aerial vehicle is currently located (i.e. the target unmanned aerial vehicle does not perform patrol).
And a substep 28, if the weighted sum is smaller than the preset average value, determining the street lamp interval number based on the environmental parameter average value corresponding to each target street lamp pole sublink for each target street lamp pole sublink, wherein the street lamp interval number corresponding to the larger environmental parameter average value is larger, and the street lamp interval number corresponding to the smaller environmental parameter average value is smaller (so that the problem of poor stability caused by excessive patrol of the target unmanned aerial vehicle in an unstable environment region can be solved).
In the substep 29, for each target street light pole sub-link, at least one street light pole is determined according to the number of the corresponding street light intervals among the multiple street light poles included in the target street light pole sub-link, and the determined street light pole is used as the target street light pole of the target street light pole sub-link (for example, in combination with the above example, for the target street light pole sub-link of "light pole 2, light pole 3, and light pole 4", if the number of the corresponding street light intervals is 1, the light pole 1 and the light pole 4 can be used as the target street light poles.
And a substep 30 of generating target flight trajectory information of the target unmanned aerial vehicle based on the obtained target street lamp post.
Optionally, in the above example, for the sub-step 11 or the sub-step 22, a specific manner of dividing the target light pole link is not limited, and may be selected according to an actual application requirement.
For example, in an alternative example, the step of dividing the target street light pole link to obtain a plurality of target street light pole sub-links may include:
step one, aiming at every two adjacent street lamp poles in the target street lamp pole link, calculating a distance parameter between the two adjacent street lamp poles to obtain a plurality of distance parameters;
secondly, comparing each distance parameter with a preset distance parameter;
taking two adjacent street lamp poles corresponding to each distance parameter smaller than the preset distance parameter as link dividing positions, wherein the two adjacent street lamp poles are respectively positioned at two sides of the link dividing positions, so that the two adjacent street lamp poles respectively belong to different target street lamp pole sublinks;
and fourthly, dividing the target street lamp pole link into a plurality of target street lamp pole sub-links based on the link dividing positions (for example, the target street lamp pole link is specific to a lamp pole 2, a lamp pole 3, a lamp pole 4, a lamp pole 5 and a lamp pole 1. if the distance parameter between the lamp pole 4 and the lamp pole 5 is greater than the preset distance parameter, two target street lamp pole sub-links can be obtained, namely the lamp pole 2, the lamp pole 3, the lamp pole 4 and the lamp pole 5 and the lamp pole 1 respectively).
For another example, in another alternative example, the step of dividing the target street light pole link to obtain a plurality of target street light pole sub-links may include:
the method comprises the steps that firstly, for every two adjacent street lamp poles in a target street lamp pole link, an environmental parameter difference value between the two adjacent street lamp poles is calculated to obtain a plurality of environmental parameter difference values;
secondly, comparing each environmental parameter difference value with a preset difference value;
taking two adjacent street lamp poles corresponding to each environmental parameter difference value larger than the preset difference value as a link dividing position, wherein the two adjacent street lamp poles are respectively positioned at two sides of the link dividing position, so that the two adjacent street lamp poles respectively belong to different target street lamp pole sublinks;
and fourthly, dividing the target street lamp pole link into a plurality of target street lamp pole sub-links based on the link dividing positions (for example, the target street lamp pole link is specific to a lamp pole 2, a lamp pole 3, a lamp pole 4, a lamp pole 5 and a lamp pole 1. if the environmental parameter difference between the lamp pole 4 and the lamp pole 5 is larger than a preset difference, two target street lamp pole sub-links can be obtained, namely the lamp pole 2, the lamp pole 3, the lamp pole 4 and the lamp pole 5 and the lamp pole 1 respectively).
In a third example, in order to improve the stability of the flight of the target drone with a certain probability and to take into account the requirement of a large area for the patrol, step S110 may comprise sub-steps 31-38.
And a substep 31, sequentially forming a target street lamp pole link based on the adjacent relation between the street lamp poles along a direction different from the direction having the minimum distance from the starting point to the terminal point by taking the street lamp pole where the target unmanned aerial vehicle is currently located as the starting point and taking the street lamp pole adjacent to the street lamp pole as the terminal point.
And a substep 32 of determining an i-2 th street light pole, an i-1 th street light pole, and an i-th street light pole in the target street light pole link, wherein the i-2 th street light pole is a previous street light pole of the i-1 th street light pole, the i-1 th street light pole is a previous street light pole of the i-th street light pole, and i is a positive integer greater than 2 (for example, the first street light pole, the second street light pole, and the third street light pole are taken as a group, the second street light pole, the third street light pole, and the fourth street light pole are taken as a group, and so on).
And a substep 33 of obtaining a first environmental parameter in the range of the area where the i-2 th street lamp post is located, a second environmental parameter in the range of the area where the i-1 th street lamp post is located, and a third environmental parameter in the range of the area where the i-th street lamp post is located.
And substep 34, calculating a difference between the first environmental parameter and the second environmental parameter to obtain a first difference, calculating a difference between the second environmental parameter and the third environmental parameter to obtain a second difference, and using the first difference and the second difference as a first reference environmental parameter and a second reference environmental parameter of the i-1 th street lamp post respectively.
A substep 35 of determining whether the second reference environment parameter is greater than a preset reference environment parameter (wherein the higher the stability requirement, the larger the preset reference environment parameter may be).
And a substep 36, if the second reference environmental parameter is less than or equal to the preset reference environmental parameter, taking the (i-1) th street light pole as a target street light pole when the second environmental parameter and the third environmental parameter are less than a preset target environmental parameter (where the higher the requirement for stability is, the larger the preset target environmental parameter can be), and taking the (i) th street light pole as a target street light pole when a charging device is disposed on the apron of the (i-1) th street light pole, wherein at least a charging device (the charging device may be a wireless induction charging device, so that the target unmanned aerial vehicle can be charged when parked on the apron, so as to improve the continuous flight capability of the target unmanned aerial vehicle).
And a substep 37, if the second reference environmental parameter is greater than the preset reference environmental parameter, taking the i-2 th street lamp post as a target street lamp post when the first environmental parameter and the second environmental parameter are less than the preset target environmental parameter, and taking the i-1 st street lamp post as the target street lamp post when the apron of the i-2 th street lamp post is provided with the charging device.
And a substep 38 of generating target flight trajectory information of the target unmanned aerial vehicle based on the obtained target street light pole.
In a fourth example, in order to improve the stability of the flight of the target drone with a certain probability and to take into account the need of a large region of the patrol, step S110 may comprise sub-steps 40-49.
And a substep 40, taking the street lamp pole where the target unmanned aerial vehicle is located at present as a starting point, taking the street lamp pole adjacent to the street lamp pole as an end point, and sequentially forming a target street lamp pole link based on the adjacent relation between the street lamp poles along a direction different from the direction with the minimum distance from the starting point to the end point.
And a substep 41 of determining, for each street light pole in the target street light pole link, an environmental parameter within the area range in which the street light pole is located.
And a substep 42 of comparing, for each street light pole in the target street light pole link, the environmental parameter corresponding to the street light pole with a preset parameter.
And a substep 43 of removing, from the target street light pole link, street light poles having an environmental parameter greater than the preset parameter (wherein the higher the requirement for stability, the smaller the preset parameter may be), and forming a new target street light pole link based on the retained street light poles.
And substep 44, determining, for each adjacent three street light poles in the new target street light pole link, a distance parameter between a first street light pole and a third street light pole in the adjacent three street light poles (for example, the new target street light pole link is "pole 2, pole 3, pole 4, pole 5, pole 1", the first adjacent three street light poles are pole 2, pole 3, pole 4, and the distance parameter between pole 2 and pole 4 needs to be determined).
And substep 45, determining, for each adjacent three street light poles in the new target street light pole link, an environmental parameter difference between a first street light pole and a third street light pole of the adjacent three street light poles (for example, in combination with the foregoing example, for the first adjacent three street light poles being the lamp poles 2, 3, and 4, the environmental parameter difference between the lamp poles 2 and 4 needs to be determined).
And a substep 46, determining, for each adjacent three street light poles in the new target street light pole link, whether a second street light pole of the adjacent three street light poles is a target street light pole based on the distance parameter and the environmental parameter difference corresponding to the adjacent three street light poles (for example, if the distance parameter is large and the environmental parameter difference is large, the second street light pole cannot be used as the target street light pole, for example, a sum of the distance parameter and the environmental parameter residual value after normalization may be calculated, or may be a weighted sum, and then, determining whether the sum is greater than a preset value, and if the sum is not greater than the preset value, the second street light pole may be used as the target street light pole, wherein the higher the requirement for stability is, the smaller the preset value may be).
And a substep 47, if a second street lamp pole of the three adjacent street lamp poles is used as a target street lamp pole, taking all the three adjacent street lamp poles as the target street lamp poles.
And substep 48, if the second of the three adjacent street light poles is not used as the target street light pole, using both the first street light pole and the second street light pole as the target street light poles.
And a substep 49 of generating target flight trajectory information of the target unmanned aerial vehicle based on the obtained target street light pole.
In the second aspect, it should be noted that, in step S120, a specific manner of sending the target flight trajectory information to the target unmanned aerial vehicle is not limited, and may be selected according to actual application requirements.
For example, in an alternative example, in order to ensure effective transmission of target flight trajectory information, step S120 may include the following sub-steps:
firstly, acquiring current position information of the target unmanned aerial vehicle; secondly, judging whether the target unmanned aerial vehicle is located in a target first area range where the cloud platform server is located or not based on the current position information (wherein the target first area range is determined based on the maximum capacity range of information sent by the cloud platform server); and then, if the target unmanned aerial vehicle is located in the first area range of the target, the target flight trajectory information is sent to the target unmanned aerial vehicle.
Optionally, in order to send the target flight trajectory information to the target unmanned aerial vehicle when the target unmanned aerial vehicle is not located in the target first area range, in this embodiment, the cloud platform server is further communicatively connected with a plurality of second state monitoring devices, and the plurality of second state monitoring devices are respectively disposed in the plurality of street lamp poles and are set in different street lamp poles with the cloud platform server. Based on this, step S120 may further include the following sub-steps:
firstly, if the target unmanned aerial vehicle is not located in the target first area range, determining target second state monitoring equipment in the plurality of second state monitoring equipment based on the current position information, wherein the target unmanned aerial vehicle is located in the target second area range where the target second state monitoring equipment is located; secondly, the target flight trajectory information is sent to the target second state monitoring device, so that the target second state monitoring device sends the target flight trajectory information to the target unmanned aerial vehicle (that is, the target second state monitoring device can forward the target flight trajectory information).
It can be understood that the specific manner of forwarding the target flight trajectory information through the target second state monitoring device is not limited, and may be selected according to the actual application requirements.
For example, in one alternative example, forwarding may be based on the following sub-steps:
firstly, determining whether the target second state monitoring equipment is positioned in the target first area range; secondly, if the target second state monitoring equipment is located in the target first area range, the target flight track information is sent to the target second state monitoring equipment; then, if the target second state monitoring device is not located in the target first area range, sequentially determining at least one other state monitoring device based on a preset shortest distance rule; and finally, the target flight path information is sent to the at least one other state monitoring device, wherein the at least one other state monitoring device is used for sending the target flight path information to the target second state monitoring device, a first other state monitoring device in the at least one other state monitoring device is located in the target first area range, and the target second state monitoring device is located in the second area range where the last other state monitoring device is located. (for example, the target second state monitoring device is located in the information sending range of the device 1, the device 1 is located in the information sending range of the device 2, and the device 2 is located in the information sending range of the first monitoring device, that is, the target first area range, so that the first monitoring device can send the target flight trajectory information to the device 2, the device 2 sends the target flight trajectory information to the device 1 again, the device 1 sends the target second state monitoring device again, and the target second state monitoring device sends the target unmanned aerial vehicle again, so that the target unmanned aerial vehicle can obtain the target flight trajectory information).
In the third aspect, it should be noted that, in step S130, a specific manner of obtaining the monitoring screen is not limited, and may be selected according to actual application requirements.
For example, in an alternative example, step S130 may include the following sub-steps:
each time the target unmanned aerial vehicle reaches one target street lamp pole and stops at the target street lamp pole, a target monitoring picture sent by the target unmanned aerial vehicle is obtained, wherein the target monitoring picture is a monitoring picture shot in the process that the target unmanned aerial vehicle flies from the last target street lamp pole to the current target street lamp pole (for example, after the target unmanned aerial vehicle flies from the first target street lamp pole to the second target street lamp pole, the monitoring picture formed in the shooting process can be sent to the cloud platform server, so that the cloud platform server can obtain the monitoring picture, and then, after the target unmanned aerial vehicle flies from the second target street lamp pole to the third target street lamp pole, the monitoring picture formed in the shooting process can be sent to the cloud platform server).
In order to ensure effective transmission of the monitoring picture, in this embodiment, the cloud platform server is in communication connection with a plurality of second state monitoring devices, the plurality of second state monitoring devices are respectively arranged in the plurality of street lamp poles, and are arranged on different street lamp poles with the cloud platform server. Based on this, based on the above example, the step of obtaining the target monitoring picture sent by the target unmanned aerial vehicle each time the target unmanned aerial vehicle reaches one target street light pole and stops at the target street light pole may include:
firstly, when the target unmanned aerial vehicle reaches one target street lamp pole and stops at the target street lamp pole each time, if the cloud platform server is positioned at the target street lamp pole, a target monitoring picture sent by the target unmanned aerial vehicle is obtained;
secondly, when the target unmanned aerial vehicle reaches one target street light pole and stops at the target street light pole each time, if the cloud platform server is not located at the target street light pole, a target monitoring picture sent by the target unmanned aerial vehicle is obtained through second state monitoring equipment on the target street light pole, wherein the second state monitoring equipment is used for sending the target monitoring picture to the cloud platform server, or sending the target monitoring picture to the cloud platform server through other second state monitoring equipment (wherein, the specific mode can refer to the method for sending the target flight trajectory information, and the description is omitted herein one by one).
Based on the same inventive concept, embodiments of the present invention provide a computer-readable storage medium; the computer readable storage medium has stored therein instructions that, when executed, cause a computer to perform the drone apron monitoring method. An embodiment of the present invention provides a computer-readable storage medium; the computer-readable storage medium has stored therein a computer program which, when executed, implements the drone apron monitoring method.
In summary, according to the method for monitoring the unmanned aerial vehicle apron, the target flight trajectory information of the target unmanned aerial vehicle is formed by selecting at least one target street lamp pole from the plurality of street lamp poles forming the ring shape, so that the flight trajectory of the target unmanned aerial vehicle, namely the patrol trajectory, can present a ring-shaped rule. So, can be so that target unmanned aerial vehicle's patrolling orbit is more reasonable to improve the reliability of control, and then improve the unreasonable problem of control that exists among the current unmanned aerial vehicle monitoring technology, make and have higher practical value. The above description is only a preferred embodiment of the present invention and is not intended to limit the present invention, and various modifications and changes may be made by those skilled in the art. Any modification, equivalent replacement, or improvement made within the spirit and principle of the present invention should be included in the protection scope of the present invention.
Claims (10)
1. The unmanned aerial vehicle parking apron monitoring method is applied to a cloud platform server, the cloud platform server is arranged on one of a plurality of street lamp poles, and each street lamp pole is respectively provided with a parking apron for parking an unmanned aerial vehicle, and the unmanned aerial vehicle parking apron monitoring method comprises the following steps:
generating target flight track information of a target unmanned aerial vehicle according to preset conditions, wherein the target flight track information comprises track information of each target street lamp pole which is required to pass by the target unmanned aerial vehicle in sequence for one-time flight inspection, the target street lamp pole is at least one, the street lamp poles form a ring shape, and any three adjacent street lamp poles are not on the same straight line;
sending the target flight trajectory information to the target unmanned aerial vehicle, wherein the target unmanned aerial vehicle flies to each target street lamp pole in sequence based on the target flight trajectory information;
and acquiring a monitoring picture shot by the target unmanned aerial vehicle in the process of flying to each target street lamp pole to obtain at least one monitoring picture.
2. The drone apron monitoring method of claim 1, wherein the step of sending the target flight trajectory information to the target drone includes:
acquiring current position information of the target unmanned aerial vehicle;
judging whether the target unmanned aerial vehicle is located in a target first area range where the cloud platform server is located or not based on the current position information;
and if the target unmanned aerial vehicle is located in the first area range of the target, the target flight track information is sent to the target unmanned aerial vehicle.
3. The method for monitoring the unmanned aerial vehicle apron according to claim 2, wherein the cloud platform server is connected to a plurality of second state monitoring devices, the second state monitoring devices are respectively disposed on the street light poles and are disposed on different street light poles from the cloud platform server, and the step of sending the target flight trajectory information to the target unmanned aerial vehicle further comprises:
if the target unmanned aerial vehicle is not located in the target first area range, determining target second state monitoring equipment in the plurality of second state monitoring equipment based on the current position information, wherein the target unmanned aerial vehicle is located in the target second area range where the target second state monitoring equipment is located;
and sending the target flight track information to the target second state monitoring equipment so that the target second state monitoring equipment sends the target flight track information to the target unmanned aerial vehicle.
4. The unmanned airplane apron monitoring method according to claim 3, wherein the step of sending the target flight trajectory information to the target second state monitoring device comprises:
determining whether the target second state monitoring device is located in the target first area range;
if the target second state monitoring equipment is located in the target first area range, the target flight track information is sent to the target second state monitoring equipment;
if the target second state monitoring device is not located in the target first area range, sequentially determining at least one other state monitoring device based on a preset shortest distance rule;
and sending the target flight track information to the at least one other state monitoring device, wherein the at least one other state monitoring device is used for sending the target flight track information to the target second state monitoring device, a first other state monitoring device in the at least one other state monitoring device is located in the target first area range, and the target second state monitoring device is located in the second area range where the last other state monitoring device is located.
5. The method for monitoring the unmanned aerial vehicle apron according to claim 1, wherein the step of obtaining the monitoring picture shot by the target unmanned aerial vehicle during the process of flying to each target street light pole comprises:
and when the target unmanned aerial vehicle reaches one target street lamp pole and stops at the target street lamp pole each time, acquiring a target monitoring picture sent by the target unmanned aerial vehicle, wherein the target monitoring picture is a monitoring picture shot in the process that the target unmanned aerial vehicle flies to the current target street lamp pole from the last target street lamp pole.
6. The method for monitoring the unmanned aerial vehicle apron according to claim 5, wherein the cloud platform server is connected with a plurality of second state monitoring devices, the second state monitoring devices are respectively disposed on the street lamp poles and are disposed on different street lamp poles from the cloud platform server, and the step of obtaining the target monitoring picture sent by the target unmanned aerial vehicle each time the target unmanned aerial vehicle reaches one target street lamp pole and stops on the target street lamp pole comprises:
when the target unmanned aerial vehicle reaches one target street lamp pole and stops at the target street lamp pole each time, if the cloud platform server is located at the target street lamp pole, acquiring a target monitoring picture sent by the target unmanned aerial vehicle;
when the target unmanned aerial vehicle reaches one target street lamp pole and stops at the target street lamp pole each time, if the cloud platform server is not located at the target street lamp pole, a target monitoring picture sent by the target unmanned aerial vehicle is obtained through second state monitoring equipment on the target street lamp pole, wherein the second state monitoring equipment is used for sending the target monitoring picture to the cloud platform server, or sending the target monitoring picture to the cloud platform server through other second state monitoring equipment.
7. The unmanned aerial vehicle apron monitoring method according to any one of claims 1 to 6, wherein the step of generating target flight trajectory information of the target unmanned aerial vehicle according to preset conditions comprises:
sequentially forming a target street lamp pole link based on the adjacent relation between the street lamp poles along a direction different from the direction with the minimum distance from the starting point to the terminal point by taking the street lamp pole where the target unmanned aerial vehicle is located as the starting point and taking the street lamp pole adjacent to the street lamp pole as the terminal point;
dividing the target street lamp post link to obtain a plurality of target street lamp post sub-links, wherein each target street lamp post sub-link comprises a plurality of street lamp posts;
regarding each two adjacent target street lamp post sublinks, taking a front street lamp post and a rear street lamp post at the division positions of the two adjacent target street lamp post sublinks as reference street lamp posts;
for each two adjacent target street lamp post sub-links, allocating the reference street lamp post corresponding to the two adjacent target street lamp post sub-links to the previous target street lamp post sub-link at the corresponding division position to obtain a first target street lamp post sub-link, and taking the allocated next target street lamp post sub-link as a second target street lamp post sub-link;
for each two adjacent target street lamp post sub-links, allocating the reference street lamp post corresponding to the two adjacent target street lamp post sub-links to a next target street lamp post sub-link at a corresponding division position to obtain a third target street lamp post sub-link, and taking the allocated previous target street lamp post sub-link as a fourth target street lamp post sub-link;
for the first target street lamp post sublink and the second target street lamp post sublink corresponding to each two adjacent target street lamp post sublinks, calculating a first environmental parameter mean value in an area range where street lamp posts are located and included in the first target street lamp post sublink, and a second environmental parameter mean value in an area range where street lamp posts are located and included in the second target street lamp post sublink, and calculating a difference value between the first environmental parameter mean value and the second environmental parameter mean value to obtain a first difference value;
for the third target street lamp post sublink and the fourth target street lamp post sublink corresponding to each two adjacent target street lamp post sublinks, calculating a third environmental parameter mean value in an area range where street lamp posts are located and included in the third target street lamp post sublink, and a fourth environmental parameter mean value in an area range where street lamp posts are located and included in the fourth target street lamp post sublink, and calculating a difference value between the third environmental parameter mean value and the fourth environmental parameter mean value to obtain a second difference value;
for each two adjacent target street lamp post sublinks, calculating a fifth environmental parameter mean value in an area range where a street lamp post is located, which is included in a previous target street lamp post sublink, and a sixth environmental parameter mean value in an area range where a street lamp post is located, which is included in a next target street lamp post sublink, and calculating a difference value between the fifth environmental parameter mean value and the sixth environmental parameter mean value to obtain a third difference value;
for each two adjacent target street lamp post sub-links, taking the difference value with the minimum value in the first difference value, the second difference value and the third difference value corresponding to the two adjacent target street lamp post sub-links as the target difference value of the two adjacent target street lamp post sub-links;
for a target difference value of each two adjacent target street lamp post sublinks, determining a street lamp post from street lamp posts included in a previous target street lamp post sublink in the two target street lamp post sublinks corresponding to the target difference value as a target street lamp post corresponding to the target difference value;
and generating target flight track information of the target unmanned aerial vehicle based on the obtained target street lamp post.
8. The unmanned aerial vehicle apron monitoring method according to any one of claims 1 to 6, wherein the step of generating target flight trajectory information of the target unmanned aerial vehicle according to preset conditions comprises:
sequentially forming a target street lamp pole link based on the adjacent relation between the street lamp poles along a direction different from the direction with the minimum distance from the starting point to the terminal point by taking the street lamp pole where the target unmanned aerial vehicle is located as the starting point and taking the street lamp pole adjacent to the street lamp pole as the terminal point;
dividing the target street lamp post link to obtain a plurality of target street lamp post sub-links, wherein each target street lamp post sub-link comprises a plurality of street lamp posts;
acquiring the number of the street lamp poles included in each target street lamp pole sub-link;
acquiring an environmental parameter mean value of each target street lamp post sublink in the area range of the street lamp post in which the target street lamp post sublink is located;
for each target street lamp post sublink, determining a weighted sum value of the corresponding environmental parameter mean value based on the number of the lamp posts corresponding to the target street lamp post sublink;
judging whether the weighted sum is larger than a preset average value or not;
if the weighted sum is greater than or equal to the preset average value, generating target flight track information only including the street lamp post where the target unmanned aerial vehicle is located currently;
if the weighted sum is smaller than the preset average value, determining the street lamp interval number for each target street lamp post sublink based on the environmental parameter average value corresponding to the target street lamp post sublink, wherein the street lamp interval number corresponding to the larger environmental parameter average value is larger, and the street lamp interval number corresponding to the smaller environmental parameter average value is smaller;
for each target street lamp post sub-link, determining at least one street lamp post in a plurality of street lamp posts included in the target street lamp post sub-link according to the corresponding street lamp interval quantity, and using the street lamp post as a target street lamp post of the target street lamp post sub-link;
and generating target flight track information of the target unmanned aerial vehicle based on the obtained target street lamp post.
9. A cloud platform server, characterized in that the cloud platform server comprises a processor and a memory which are communicated with each other, and the processor is used for realizing the method of any one of claims 1 to 8 by calling and running a computer program in the memory.
10. A computer-readable storage medium having stored therein instructions that, when executed, cause a computer to perform the method of any one of claims 1-8.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202011632645.9A CN112363537B (en) | 2020-12-31 | 2020-12-31 | Unmanned aerial vehicle parking apron monitoring method, cloud platform server and storage medium |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202011632645.9A CN112363537B (en) | 2020-12-31 | 2020-12-31 | Unmanned aerial vehicle parking apron monitoring method, cloud platform server and storage medium |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN112363537A CN112363537A (en) | 2021-02-12 |
| CN112363537B true CN112363537B (en) | 2022-02-18 |
Family
ID=74534740
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202011632645.9A Active CN112363537B (en) | 2020-12-31 | 2020-12-31 | Unmanned aerial vehicle parking apron monitoring method, cloud platform server and storage medium |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN112363537B (en) |
Families Citing this family (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114911271B (en) * | 2022-06-23 | 2023-05-09 | 深圳市多翼创新科技有限公司 | A wide-area distributed collaborative operation system and method based on cloud-based UAV |
| CN114815902B (en) * | 2022-06-29 | 2022-10-14 | 深圳联和智慧科技有限公司 | Unmanned aerial vehicle monitoring method, system, server and storage medium |
Citations (15)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR101043419B1 (en) * | 2010-12-15 | 2011-06-22 | 썬파크 주식회사 | Safety management system and safety management method using energy-saving street lights |
| WO2013077598A1 (en) * | 2011-11-21 | 2013-05-30 | 엘이오테크 주식회사 | Led safety light having a surveillance camera mounted thereon to prevent the scattering of light |
| CN103370571A (en) * | 2011-01-19 | 2013-10-23 | 皇家飞利浦电子股份有限公司 | A lighting device and a luminaire comprising the lighting device |
| CN204922742U (en) * | 2015-08-07 | 2015-12-30 | 上海臻恒光电系统有限公司 | Intelligent street lamp of 360 degree integrated panorama clitellum camera lenses |
| CN105627237A (en) * | 2016-01-08 | 2016-06-01 | 四川蜀旺科技有限公司 | Wireless monitor solar street lamp and monitoring method thereof |
| CN205546138U (en) * | 2016-02-04 | 2016-08-31 | 湖南东琴电子工程股份有限公司 | Wisdom street lamp system based on 6LoWPAN |
| WO2018101666A1 (en) * | 2016-12-01 | 2018-06-07 | Samsung Electronics Co., Ltd. | Unmanned aerial vehicle |
| CN108230678A (en) * | 2018-03-01 | 2018-06-29 | 温仕鑫 | Using the traffic route monitoring system of monitoring unmanned |
| CN108775531A (en) * | 2018-07-11 | 2018-11-09 | 上海罗曼照明科技股份有限公司 | It can start and monitor the multi-functional street lamp and control method of unmanned plane during flying state |
| CN109740583A (en) * | 2016-09-20 | 2019-05-10 | 吴玉芳 | LED street lamp and intelligent video monitoring system based on recognition of face |
| CN110345411A (en) * | 2018-04-03 | 2019-10-18 | 上海三思电子工程有限公司 | Wisdom street lamp, system, controlling terminal, aircraft, method of control and medium |
| CN210858199U (en) * | 2019-09-28 | 2020-06-26 | 广东恒宇信息科技有限公司 | City thing networking wisdom pole |
| CN111767852A (en) * | 2020-06-29 | 2020-10-13 | 深圳联和智慧科技有限公司 | Urban road well lid supervision system and method based on intelligent lamp pole |
| CN211822074U (en) * | 2020-05-15 | 2020-10-30 | 珠海欧朗特光电科技有限公司 | A smart street light that can be used for real-time monitoring |
| CN111846221A (en) * | 2020-03-26 | 2020-10-30 | 同济大学 | A UAV and its smart street light system |
Family Cites Families (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US6462775B1 (en) * | 1996-11-21 | 2002-10-08 | Detection Dynamics, Inc. | Apparatus within a street lamp for remote surveillance having directional antenna |
| US9734397B1 (en) * | 2016-11-04 | 2017-08-15 | Loveland Innovations, LLC | Systems and methods for autonomous imaging and structural analysis |
| CN108255196A (en) * | 2016-12-29 | 2018-07-06 | 上海三思电子工程有限公司 | Wisdom street lamp, wisdom road lamp system and its method for controlling unmanned plane |
| CN108255191A (en) * | 2016-12-29 | 2018-07-06 | 上海三思电子工程有限公司 | Unmanned plane management-control method and wisdom road lamp system |
| CN110750103B (en) * | 2018-07-24 | 2021-03-19 | 东旭光电科技股份有限公司 | Unmanned aerial vehicle navigation method and device, street lamp and readable storage medium |
-
2020
- 2020-12-31 CN CN202011632645.9A patent/CN112363537B/en active Active
Patent Citations (15)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR101043419B1 (en) * | 2010-12-15 | 2011-06-22 | 썬파크 주식회사 | Safety management system and safety management method using energy-saving street lights |
| CN103370571A (en) * | 2011-01-19 | 2013-10-23 | 皇家飞利浦电子股份有限公司 | A lighting device and a luminaire comprising the lighting device |
| WO2013077598A1 (en) * | 2011-11-21 | 2013-05-30 | 엘이오테크 주식회사 | Led safety light having a surveillance camera mounted thereon to prevent the scattering of light |
| CN204922742U (en) * | 2015-08-07 | 2015-12-30 | 上海臻恒光电系统有限公司 | Intelligent street lamp of 360 degree integrated panorama clitellum camera lenses |
| CN105627237A (en) * | 2016-01-08 | 2016-06-01 | 四川蜀旺科技有限公司 | Wireless monitor solar street lamp and monitoring method thereof |
| CN205546138U (en) * | 2016-02-04 | 2016-08-31 | 湖南东琴电子工程股份有限公司 | Wisdom street lamp system based on 6LoWPAN |
| CN109740583A (en) * | 2016-09-20 | 2019-05-10 | 吴玉芳 | LED street lamp and intelligent video monitoring system based on recognition of face |
| WO2018101666A1 (en) * | 2016-12-01 | 2018-06-07 | Samsung Electronics Co., Ltd. | Unmanned aerial vehicle |
| CN108230678A (en) * | 2018-03-01 | 2018-06-29 | 温仕鑫 | Using the traffic route monitoring system of monitoring unmanned |
| CN110345411A (en) * | 2018-04-03 | 2019-10-18 | 上海三思电子工程有限公司 | Wisdom street lamp, system, controlling terminal, aircraft, method of control and medium |
| CN108775531A (en) * | 2018-07-11 | 2018-11-09 | 上海罗曼照明科技股份有限公司 | It can start and monitor the multi-functional street lamp and control method of unmanned plane during flying state |
| CN210858199U (en) * | 2019-09-28 | 2020-06-26 | 广东恒宇信息科技有限公司 | City thing networking wisdom pole |
| CN111846221A (en) * | 2020-03-26 | 2020-10-30 | 同济大学 | A UAV and its smart street light system |
| CN211822074U (en) * | 2020-05-15 | 2020-10-30 | 珠海欧朗特光电科技有限公司 | A smart street light that can be used for real-time monitoring |
| CN111767852A (en) * | 2020-06-29 | 2020-10-13 | 深圳联和智慧科技有限公司 | Urban road well lid supervision system and method based on intelligent lamp pole |
Also Published As
| Publication number | Publication date |
|---|---|
| CN112363537A (en) | 2021-02-12 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN114035614B (en) | Unmanned aerial vehicle autonomous inspection method and system based on prior information and storage medium | |
| CN113342046B (en) | Power transmission line unmanned aerial vehicle routing inspection path optimization method based on ant colony algorithm | |
| WO2022142664A1 (en) | Traffic information transmission method and apparatus, medium, electronic device and program product | |
| CN112363537A (en) | Unmanned aerial vehicle parking apron monitoring method, cloud platform server and storage medium | |
| CN113129596B (en) | Travel data processing method, travel data processing device, travel data processing apparatus, storage medium, and program product | |
| CN112687107B (en) | Perception data acquisition method and device | |
| CN111142883A (en) | Vehicle computing task offloading method based on SDN architecture | |
| CN111627241B (en) | Method and device for generating intersection vehicle queuing information | |
| CN109961657B (en) | Unmanned Aerial Vehicle (UAV) allocation method, UAV and console | |
| CN113619599B (en) | Remote driving method, system, device and storage medium | |
| EP4243479A1 (en) | Data transmission method, user equipment, and storage medium | |
| EP4455878A1 (en) | Map scene rendering method and apparatus, server, terminal, computer-readable storage medium, and computer program product | |
| CN114594790A (en) | A method and system for multi-unmanned aerial vehicle patrolling path planning in distribution network | |
| CN115407803A (en) | Target monitoring method and device based on unmanned aerial vehicle | |
| CN115035484A (en) | Road intersection monitoring system and method based on deep learning and ground-air coordination | |
| CN115877865A (en) | Unmanned aerial vehicle inspection method and device and unmanned aerial vehicle inspection system | |
| CN113807209B (en) | Parking space detection method and device, electronic equipment and storage medium | |
| CN115202691A (en) | Remote upgrading method and system based on vehicle end FOTA | |
| CN113095266A (en) | Angle identification method, device and equipment | |
| CN117842097A (en) | Vehicle control method, device, equipment and storage medium based on automatic driving | |
| CN118311978B (en) | A transmission line collaborative inspection system based on drones | |
| CN120299234A (en) | Vehicle trajectory prediction method, prediction model training method and road-side equipment | |
| CN110996292B (en) | An implementation method of a safety alarm system based on the Internet of Vehicles | |
| CN114944078B (en) | Information processing method, apparatus, device, storage medium, and computer program product | |
| US11722206B2 (en) | Wireless communication system |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| TR01 | Transfer of patent right | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20220929 Address after: 511458 Room 101, 30 Yongxing street, jiuwangmiao village, Nansha street, Nansha District, Guangzhou City, Guangdong Province (office only) Patentee after: GUANGDONG TESHINENG INTELLIGENT TECHNOLOGY Co.,Ltd. Address before: 510700 Guangzhou Zhiwu Internet Technology Co., Ltd., room 220-239, building 1, No. 9, Shenzhou Road, Huangpu District, Guangzhou, Guangdong Patentee before: Guangzhou smart Internet Technology Co.,Ltd. |