CN112031051A - Metamorphic parallel six-connecting-rod bucket mechanism applied to face shovel excavator - Google Patents
Metamorphic parallel six-connecting-rod bucket mechanism applied to face shovel excavator Download PDFInfo
- Publication number
- CN112031051A CN112031051A CN202010839149.4A CN202010839149A CN112031051A CN 112031051 A CN112031051 A CN 112031051A CN 202010839149 A CN202010839149 A CN 202010839149A CN 112031051 A CN112031051 A CN 112031051A
- Authority
- CN
- China
- Prior art keywords
- bucket
- boom
- hydraulic
- hydraulic cylinders
- hinged
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images
Classifications
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F3/00—Dredgers; Soil-shifting machines
- E02F3/04—Dredgers; Soil-shifting machines mechanically-driven
- E02F3/28—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets
- E02F3/30—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets with a dipper-arm pivoted on a cantilever beam, i.e. boom
- E02F3/301—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets with a dipper-arm pivoted on a cantilever beam, i.e. boom with more than two arms (boom included), e.g. two-part boom with additional dipper-arm
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F3/00—Dredgers; Soil-shifting machines
- E02F3/04—Dredgers; Soil-shifting machines mechanically-driven
- E02F3/28—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets
- E02F3/36—Component parts
- E02F3/42—Drives for dippers, buckets, dipper-arms or bucket-arms
- E02F3/425—Drive systems for dipper-arms, backhoes or the like
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Mining & Mineral Resources (AREA)
- Civil Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Structural Engineering (AREA)
- Operation Control Of Excavators (AREA)
Abstract
Description
技术领域technical field
本发明涉及挖掘机技术领域,更具体的说是涉及一种应用于正铲挖掘机上的变胞并联六连杆铲斗机构。The invention relates to the technical field of excavators, in particular to a metamorphic parallel six-link bucket mechanism applied to a front shovel excavator.
背景技术Background technique
特大型正铲矿用液压挖掘机是煤矿露天开采的主要工具,露天矿在开采前需要用特大型正铲矿用液压挖掘机进行剥离作业,将矿体上覆盖的土壤或岩石剥离,在开采过程中挖掘装载破碎后的煤岩,工作环境恶劣,同时要求挖掘装备具有足够高的开采效率和能量利用率。Hydraulic excavators for oversized front shovels are the main tools for open-pit mining in coal mines. Before mining in open-pit mines, oversized hydraulic excavators for front shovels need to be used for stripping operations to strip off the soil or rocks covered on the ore body, before mining. In the process of excavating and loading broken coal and rock, the working environment is harsh, and the excavation equipment is required to have sufficiently high mining efficiency and energy utilization rate.
挖掘机的各项功能主要依靠挖掘机构来完成,我国对特大型矿用液压挖掘机的研发工作起步较晚,尤其对特大型正铲挖掘装置的研究更为贫乏。中国专利CN103437386涉及一种可自动实现铲斗提升节能和平动要求的正铲挖掘装置,特点是铲斗液压缸一端与动臂摇杆铰接,另一端与铲斗铰接,该结构液压管路位于近料石端,容易撞击或磨损损坏,影响挖掘效率。国外特大型矿用液压挖掘机制造企业主要有美国卡特彼勒公司(CATERPILLR)、德国利勃海尔公司(LIEBHERR)、日本小松株式会社(KOMATSU)及日立株式会社(HITACHI)等。其中,最具代表性的是卡特彼勒公司生产的含“强力三角”结构的矿用液压挖掘机,但是该机构因为十二连杆机构,机构复杂,容易发生位置上的奇异,工作范围小,同时该机构的动臂与斗杆姿态与铲斗液压缸参数有关,耦合关系复杂,控制较难。虽然国外厂家的特大型正铲矿用液压挖掘机技术较为成熟,但目前为止他们的产品结构类型比较单一。The functions of excavators are mainly completed by excavating mechanisms. The research and development of super-large mining hydraulic excavators in my country started late, especially the research on super-large front shovel excavation devices. Chinese patent CN103437386 relates to a front shovel excavating device that can automatically realize the requirements of bucket lifting, energy saving and translation. It is characterized in that one end of the bucket hydraulic cylinder is hinged with the boom rocker, and the other end is hinged with the bucket. The end of the material stone is easy to be damaged by impact or wear, which affects the excavation efficiency. Foreign super-large mining hydraulic excavator manufacturers mainly include Caterpillar of the United States (CATERPILLR), Liebherr of Germany (LIEBHERR), Komatsu Corporation of Japan (KOMATSU) and Hitachi Co., Ltd. (HITACHI). Among them, the most representative one is the mining hydraulic excavator with a "strong triangular" structure produced by Caterpillar. However, because of the twelve-bar linkage mechanism, the mechanism is complex, prone to singularity in position, and has a small working range. At the same time, the posture of the boom and stick of the mechanism is related to the parameters of the bucket hydraulic cylinder, the coupling relationship is complex, and the control is difficult. Although the technology of oversized hydraulic excavators for front shovel mining from foreign manufacturers is relatively mature, their product structure types are relatively simple so far.
因此,如何提供一种便于油路管线布置,能够防止管路与石料接触导致的碰撞,且易于实现动臂及斗杆姿态控制,不易于出现位置上的奇异,工作范围大,结构简单紧凑的应用于正铲挖掘机上的变胞并联六连杆铲斗机构,是本领域技术人员亟需解决的问题。Therefore, how to provide a convenient oil pipeline layout, can prevent the collision caused by the pipeline and the stone contact, and is easy to realize the attitude control of the boom and the stick, is not easy to appear strange in position, has a large working range, and has a simple and compact structure. The metamorphic parallel six-link bucket mechanism applied to the front shovel is an urgent problem to be solved by those skilled in the art.
发明内容SUMMARY OF THE INVENTION
有鉴于此,本发明提供了一种便于油路管线布置,能够防止管路与石料接触导致的碰撞,且易于实现动臂及斗杆姿态控制,不易于出现位置上的奇异,工作范围大,结构简单紧凑的应用于正铲挖掘机上的变胞并联六连杆铲斗机构。In view of this, the present invention provides a convenient oil pipeline arrangement, which can prevent the collision caused by the contact between the pipeline and the stone, and is easy to realize the attitude control of the boom and the stick. A metamorphic parallel six-link bucket mechanism applied to a front shovel with a simple and compact structure.
为了实现上述目的,本发明采用如下技术方案:In order to achieve the above object, the present invention adopts the following technical solutions:
一种应用于正铲挖掘机上的变胞并联六连杆铲斗机构,包括:A metamorphic parallel six-link bucket mechanism applied to a front shovel, comprising:
机架,frame,
动臂,所述动臂下端与所述机架顶部一侧铰接;a boom, the lower end of the boom is hinged with one side of the top of the frame;
斗杆,所述斗杆一端与所述动臂上端铰接,所述斗杆另一端铰接有铲斗;a stick, one end of the stick is hinged with the upper end of the boom, and the other end of the stick is hinged with a bucket;
两个斗杆液压缸,两个所述斗杆液压缸的缸套端部分别与所述机架另一侧顶部铰接,两个所述斗杆液压缸的活塞杆端部分别与所述斗杆中部两侧铰接;Two stick hydraulic cylinders, the cylinder liner ends of the two stick hydraulic cylinders are respectively hinged with the top of the other side of the frame, and the piston rod ends of the two stick hydraulic cylinders are respectively connected with the bucket The middle of the rod is hinged on both sides;
两个动臂液压缸,两个所述动臂液压缸的缸套端部分别与所述动臂中部两侧铰接,两个所述动臂液压缸的活塞杆端部分别与所述机架另一侧底部铰接;Two boom hydraulic cylinders, the cylinder liner ends of the two boom hydraulic cylinders are respectively hinged with both sides of the boom middle, and the piston rod ends of the two boom hydraulic cylinders are respectively connected with the frame The other side is hinged at the bottom;
两个传递臂,两个所述传递臂对称铰接在所述动臂顶部的两侧,且位于两个所述动臂液压缸的缸套端部的上方;two transmission arms, the two transmission arms are symmetrically hinged on both sides of the top of the boom, and are located above the cylinder liner ends of the two boom hydraulic cylinders;
两个铲斗液压缸,两个所述铲斗液压缸的缸套端部分别与两个传递臂的一端铰接,两个所述铲斗液压缸的活塞杆端部分别与机架另一侧顶部铰接;Two bucket hydraulic cylinders, the cylinder liner ends of the two bucket hydraulic cylinders are respectively hinged with one end of the two transmission arms, and the piston rod ends of the two bucket hydraulic cylinders are respectively connected to the other side of the frame top hinged;
两个铲斗连杆,两个所述铲斗连杆一端分别与两个所述传递臂另一端铰接,两个所述铲斗连杆另一端分别与所述铲斗铰接。Two bucket links, one end of the two bucket links are respectively hinged with the other ends of the two transmission arms, and the other ends of the two bucket links are respectively hinged with the bucket.
经由上述的技术方案可知,与现有技术相比,本发明公开提供了一种应用于正铲挖掘机上的变胞并联六连杆铲斗机构,通过将铲斗液压缸设置在机架和动臂上,使得液压管路远离石料,便于管路布置,并且防止了管路与料石接触导致的碰撞和磨损以及料石对液压系统的污染,延长了液压管路的使用寿命,降低了液压系统故障率。同时,该变胞并联六连杆铲斗机构只需控制单个的液压缸即可实现动臂及斗杆姿态控制,结构简单,无位置奇异、工作范围大。As can be seen from the above technical solutions, compared with the prior art, the present disclosure provides a metamorphic parallel six-link bucket mechanism applied to a front shovel excavator. On the arm, the hydraulic pipeline is kept away from the stone, which is convenient for pipeline layout, and prevents the collision and wear caused by the contact between the pipeline and the stone, and the pollution of the hydraulic system by the stone, which prolongs the service life of the hydraulic pipeline and reduces the hydraulic pressure. System failure rate. At the same time, the metamorphic parallel six-link bucket mechanism only needs to control a single hydraulic cylinder to realize the attitude control of the boom and the stick, with simple structure, no singular position and large working range.
附图说明Description of drawings
为了更清楚地说明本发明实施例或现有技术中的技术方案,下面将对实施例或现有技术描述中所需要使用的附图作简单地介绍,显而易见地,下面描述中的附图仅仅是本发明的实施例,对于本领域普通技术人员来讲,在不付出创造性劳动的前提下,还可以根据提供的附图获得其他的附图。In order to explain the embodiments of the present invention or the technical solutions in the prior art more clearly, the following briefly introduces the accompanying drawings that need to be used in the description of the embodiments or the prior art. Obviously, the accompanying drawings in the following description are only It is an embodiment of the present invention. For those of ordinary skill in the art, other drawings can also be obtained according to the provided drawings without creative work.
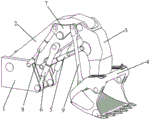
图1附图为本发明提供的一种应用于正铲挖掘机上的变胞并联六连杆铲斗机构的结构示意图。1 is a schematic structural diagram of a metamorphic parallel six-link bucket mechanism applied to a front shovel provided by the present invention.
其中:1-机架,2-动臂,3-斗杆,4-铲斗,5-斗杆液压缸,6-动臂液压缸,7-传递臂,8-铲斗液压缸,9-铲斗连杆。Among them: 1- frame, 2- boom, 3- stick, 4- bucket, 5- stick hydraulic cylinder, 6- boom hydraulic cylinder, 7- transfer arm, 8- bucket hydraulic cylinder, 9- Bucket linkage.
具体实施方式Detailed ways
下面将结合本发明实施例中的附图,对本发明实施例中的技术方案进行清楚、完整地描述,显然,所描述的实施例仅仅是本发明一部分实施例,而不是全部的实施例。基于本发明中的实施例,本领域普通技术人员在没有做出创造性劳动前提下所获得的所有其他实施例,都属于本发明保护的范围。The technical solutions in the embodiments of the present invention will be clearly and completely described below with reference to the accompanying drawings in the embodiments of the present invention. Obviously, the described embodiments are only a part of the embodiments of the present invention, but not all of the embodiments. Based on the embodiments of the present invention, all other embodiments obtained by those of ordinary skill in the art without creative efforts shall fall within the protection scope of the present invention.
本发明实施例公开了一种应用于正铲挖掘机上的变胞并联六连杆铲斗机构,包括:The embodiment of the present invention discloses a metamorphic parallel six-link bucket mechanism applied to a front shovel, comprising:
机架1,rack 1,
动臂2,动臂2下端与机架1顶部一侧铰接;
斗杆3,斗杆3一端与动臂2上端铰接,斗杆3另一端铰接有铲斗4;A stick 3, one end of the stick 3 is hinged with the upper end of the
两个斗杆液压缸5,两个斗杆液压缸5的缸套端部分别与机架1另一侧顶部铰接,两个斗杆液压缸5的活塞杆端部分别与斗杆3中部两侧铰接;Two stick
两个动臂液压缸6,两个动臂液压缸6的缸套端部分别与动臂2中部两侧铰接,两个动臂液压缸6的活塞杆端部分别与机架1另一侧底部铰接;Two boom hydraulic cylinders 6, the cylinder liner ends of the two boom hydraulic cylinders 6 are respectively hinged with both sides of the middle of the
两个传递臂7,两个传递臂7对称铰接在动臂2顶部的两侧,且位于两个动臂液压缸6的缸套端部的上方;Two
两个铲斗液压缸8,两个铲斗液压缸8的缸套端部分别与两个传递臂7的一端铰接,两个铲斗液压缸8的活塞杆端部分别与机架1另一侧顶部铰接;Two bucket
两个铲斗连杆9,两个铲斗连杆9一端分别与两个传递臂7另一端铰接,两个铲斗连杆9另一端分别与铲斗4铰接。Two
本发明的变胞并联六连杆铲斗机构,当操纵动臂2作业时,动臂2姿态只受动臂液压缸6控制,因此在动臂液压缸6的驱动作用下,能保证铲斗4近似水平提升以防止物料洒落,无须再控制铲斗液压缸8,使得控制结构更加简单。当动臂2姿态保持不变时,斗杆3姿态只受斗杆液压缸5控制,因此在斗杆液压缸5的驱动作用下,能保证铲斗4水平挖掘。当铲斗4运动时,通过铲斗液压缸8驱动传递臂7,并经铲斗连杆9带动铲斗4绕斗杆3转动。变胞的含义是在动臂、斗杆和铲斗三个不同液压缸驱动时,机构的机架边界和驱动杆不同。In the metamorphic parallel six-link bucket mechanism of the present invention, when the
本发明的变胞并联六连杆铲斗机构,将传统的十二连杆机构分解为一个四连杆主作业运动和一个六连杆自适应作业运动的串联,使得变胞并联六连杆铲斗机构更加简单,同时通过动臂液压缸或斗杆液压缸锁住两个连杆运动,达到解耦效果。具体的:主作业运动分为动臂主作业和斗杆主作业。其中,动臂主作业时,斗杆液压缸5闭锁,主作业四连杆为机架1、动臂2与斗杆3组合体、动臂液压缸6活塞杆、动臂液压缸6缸筒,自适应六连杆为机架1、动臂2与斗杆3组合体、铲斗液压缸8、传递臂7、铲斗连杆9、铲斗4;斗杆主作业时,动臂液压缸6闭锁,主作业四连杆为机架1与动臂2组合体、斗杆液压缸5活塞杆、斗杆液压缸5缸筒、斗杆3,自适应六连杆为机架1与动臂2组合体、铲斗液压缸8、传递臂7、铲斗连杆9、斗杆3、铲斗4;铲斗作业时,动臂液压缸6及斗杆液压缸5闭锁,作业六连杆为机架1和动臂2和斗杆3组合体、铲斗液压缸8活塞杆、铲斗液压缸8缸筒、传递臂7、铲斗连杆9、铲斗4。The metamorphic parallel six-link bucket mechanism of the present invention decomposes the traditional twelve-link mechanism into a series of a four-link main working motion and a six-link adaptive working motion, so that the metamorphic parallel six-link shovel The bucket mechanism is simpler, and at the same time, the movement of the two connecting rods is locked by the boom hydraulic cylinder or the stick hydraulic cylinder to achieve the decoupling effect. Specifically: the main operation movement is divided into the main operation of the boom and the main operation of the stick. Among them, during the main operation of the boom, the arm
本发明与现有的技术相比,具有以下优点:Compared with the prior art, the present invention has the following advantages:
1.铲斗液压缸两端分别与机架和传递臂铰接,方便管路固定于机架与动臂上,避免管路悬空,防止挖掘时与矿石意外撞击和磨损,同时可降低现场料石对液压系统的污染,延长液压系统管路寿命,降低液压系统故障率。1. The two ends of the bucket hydraulic cylinder are hinged with the frame and the transfer arm respectively, which is convenient for the pipeline to be fixed on the frame and the boom, avoids the pipeline hanging in the air, prevents accidental collision and wear with the ore during excavation, and can reduce the on-site stone material Pollution of the hydraulic system, prolong the life of the hydraulic system pipeline, and reduce the failure rate of the hydraulic system.
2.在动臂或斗杆作业时,该变胞并联六连杆铲斗机构由动臂或斗杆驱动,液压缸耦合性小,与“强力三角”相比,将十二连杆机构分解为一个四连杆主作业运动和一个六连杆自适应作业运动的串联,只须控制单个液压缸便可实现动臂及斗杆姿态控制。在动臂和斗杆液压缸闭锁时,可以操纵铲斗液压缸驱动变胞并联六连杆机构实现铲斗挖掘作业。2. When the boom or stick is working, the metamorphic parallel six-link bucket mechanism is driven by the boom or stick, and the coupling of the hydraulic cylinder is small. Compared with the "strong triangle", the twelve-link mechanism is decomposed It is a series of a four-link main working motion and a six-link adaptive working motion, and only needs to control a single hydraulic cylinder to realize the attitude control of the boom and the stick. When the boom and the stick hydraulic cylinder are locked, the bucket hydraulic cylinder can be operated to drive the metamorphic parallel six-bar linkage mechanism to realize the bucket excavation operation.
3.动臂作业时,其姿态只受动臂液压缸控制,在铲斗水平提升过程中,铲斗液压缸处于闭锁,动臂带动传递臂向后转动,通过动臂作为驱动元件的铲斗机构可使铲斗自适应随动运动,做到举升不撒料,且无须控制铲斗液压缸。斗杆作业时,动臂姿态保持不变时,斗杆姿态只受斗杆液压缸控制;在铲斗水平挖掘过程中,铲斗液压缸长度保持不变,动臂液压缸处于浮动工况,在重力的作用下,铲斗紧贴地面运动,在铲斗液压缸的约束下,通过斗杆作为驱动元件的铲斗机构使铲斗绕斗杆顺时针转动,自适应调整挖掘角度,实现水平挖掘,且无需操纵铲斗。因此,该结构完全满足挖掘要求,而且变胞多连杆机构仅通过控制单个液压缸便可以完成铲斗水平推压与水平提升功能。在完成水平推压与水平提升功能时,只须锁定铲斗液压缸,该变胞多连杆机构可自动调节铲斗角度,通过控制单个液压缸便可完成相应功能。3. When the boom is working, its posture is only controlled by the boom hydraulic cylinder. During the horizontal lifting of the bucket, the bucket hydraulic cylinder is locked, and the boom drives the transmission arm to rotate backwards, and the boom is used as the driving element of the bucket. The mechanism can make the bucket self-adaptive follow-up motion, so that it can lift without spreading material, and it is not necessary to control the bucket hydraulic cylinder. When the stick is working, when the boom posture remains unchanged, the stick posture is only controlled by the stick hydraulic cylinder; during the horizontal excavation of the bucket, the length of the bucket hydraulic cylinder remains unchanged, and the boom hydraulic cylinder is in a floating condition. Under the action of gravity, the bucket moves close to the ground. Under the constraint of the bucket hydraulic cylinder, the bucket rotates clockwise around the stick through the bucket mechanism with the stick as the driving element, and the digging angle is adaptively adjusted to achieve a horizontal Dig without manipulating the bucket. Therefore, the structure fully meets the excavation requirements, and the metamorphic multi-link mechanism can complete the horizontal pushing and horizontal lifting functions of the bucket only by controlling a single hydraulic cylinder. When the horizontal pushing and horizontal lifting functions are completed, it is only necessary to lock the bucket hydraulic cylinder. The metamorphic multi-link mechanism can automatically adjust the bucket angle, and the corresponding functions can be completed by controlling a single hydraulic cylinder.
4.结构紧凑、液压缸耦合性小,易于协调控制,运动分析简单。4. The structure is compact, the coupling of the hydraulic cylinder is small, it is easy to coordinate control, and the motion analysis is simple.
本说明书中各个实施例采用递进的方式描述,每个实施例重点说明的都是与其他实施例的不同之处,各个实施例之间相同相似部分互相参见即可。对于实施例公开的装置而言,由于其与实施例公开的方法相对应,所以描述的比较简单,相关之处参见方法部分说明即可。The various embodiments in this specification are described in a progressive manner, and each embodiment focuses on the differences from other embodiments, and the same and similar parts between the various embodiments can be referred to each other. As for the device disclosed in the embodiment, since it corresponds to the method disclosed in the embodiment, the description is relatively simple, and the relevant part can be referred to the description of the method.
对所公开的实施例的上述说明,使本领域专业技术人员能够实现或使用本发明。对这些实施例的多种修改对本领域的专业技术人员来说将是显而易见的,本文中所定义的一般原理可以在不脱离本发明的精神或范围的情况下,在其它实施例中实现。因此,本发明将不会被限制于本文所示的这些实施例,而是要符合与本文所公开的原理和新颖特点相一致的最宽的范围。The above description of the disclosed embodiments enables any person skilled in the art to make or use the present invention. Various modifications to these embodiments will be readily apparent to those skilled in the art, and the generic principles defined herein may be implemented in other embodiments without departing from the spirit or scope of the invention. Thus, the present invention is not intended to be limited to the embodiments shown herein, but is to be accorded the widest scope consistent with the principles and novel features disclosed herein.
Claims (1)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010839149.4A CN112031051A (en) | 2020-08-19 | 2020-08-19 | Metamorphic parallel six-connecting-rod bucket mechanism applied to face shovel excavator |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010839149.4A CN112031051A (en) | 2020-08-19 | 2020-08-19 | Metamorphic parallel six-connecting-rod bucket mechanism applied to face shovel excavator |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN112031051A true CN112031051A (en) | 2020-12-04 |
Family
ID=73577655
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202010839149.4A Pending CN112031051A (en) | 2020-08-19 | 2020-08-19 | Metamorphic parallel six-connecting-rod bucket mechanism applied to face shovel excavator |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN112031051A (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN116416566A (en) * | 2023-02-03 | 2023-07-11 | 中煤科工集团沈阳研究院有限公司 | A loading recognition method for excavators in open-pit mines based on truck dispatching system |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102720226A (en) * | 2012-06-01 | 2012-10-10 | 燕山大学 | Face shovel spadework device with movement redundancy |
| US20170009421A1 (en) * | 2014-02-17 | 2017-01-12 | Hudson Bay Holding B.V. | Articulated Operating Arm and Mobile Apparatus with Improved Mounting of Control Member |
| CN106337452A (en) * | 2016-09-06 | 2017-01-18 | 广西大学 | Three-rod four-joint tandem face-shovel excavator |
| CN106638734A (en) * | 2016-11-18 | 2017-05-10 | 广西大学 | Electric linear driven controllable connecting rod type excavator with function of locking metamorphism |
| CN107630480A (en) * | 2017-09-14 | 2018-01-26 | 莱州市厦装机械有限公司 | A kind of arm that digs can 360 degree of dress digging all-in-ones with upper rotary |
| CN111042237A (en) * | 2019-12-19 | 2020-04-21 | 中国地质大学(武汉) | Front shovel excavation mechanism that can increase the thrust of the hydraulic cylinder of the stick and the stroke of the stick |
| CN111042240A (en) * | 2019-12-19 | 2020-04-21 | 中国地质大学(武汉) | Front shovel hydraulic excavation mechanism capable of horizontal dozing |
-
2020
- 2020-08-19 CN CN202010839149.4A patent/CN112031051A/en active Pending
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102720226A (en) * | 2012-06-01 | 2012-10-10 | 燕山大学 | Face shovel spadework device with movement redundancy |
| US20170009421A1 (en) * | 2014-02-17 | 2017-01-12 | Hudson Bay Holding B.V. | Articulated Operating Arm and Mobile Apparatus with Improved Mounting of Control Member |
| CN106337452A (en) * | 2016-09-06 | 2017-01-18 | 广西大学 | Three-rod four-joint tandem face-shovel excavator |
| CN106638734A (en) * | 2016-11-18 | 2017-05-10 | 广西大学 | Electric linear driven controllable connecting rod type excavator with function of locking metamorphism |
| CN107630480A (en) * | 2017-09-14 | 2018-01-26 | 莱州市厦装机械有限公司 | A kind of arm that digs can 360 degree of dress digging all-in-ones with upper rotary |
| CN111042237A (en) * | 2019-12-19 | 2020-04-21 | 中国地质大学(武汉) | Front shovel excavation mechanism that can increase the thrust of the hydraulic cylinder of the stick and the stroke of the stick |
| CN111042240A (en) * | 2019-12-19 | 2020-04-21 | 中国地质大学(武汉) | Front shovel hydraulic excavation mechanism capable of horizontal dozing |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN116416566A (en) * | 2023-02-03 | 2023-07-11 | 中煤科工集团沈阳研究院有限公司 | A loading recognition method for excavators in open-pit mines based on truck dispatching system |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102720230B (en) | Motion redundancy face shovel excavating mechanism capable of reducing lifting energy consumption | |
| CN102720229B (en) | Motion redundancy face shovel excavating mechanism capable of optimizing lifting force | |
| CN103382730B (en) | Face shovel excavating and loading device capable of optimizing drive and stroke of bucket rod | |
| CN205224134U (en) | Excavator robotic arm and multi -functional excavator | |
| CN103603386B (en) | A kind of a new kind of working device and excavator | |
| CN102720226B (en) | Face shovel spadework device with movement redundancy | |
| WO2024012588A1 (en) | Hydraulic face shovel operation apparatus, control method, and excavator | |
| CN103382728B (en) | The crowd shovel optimizing swing arm lifting force and dipper driving excavates loading attachment | |
| CN103437386B (en) | Automatically can realize scraper bowl and promote the energy-conservation peaceful crowd shovel excavation loading attachment moving requirement | |
| CN103046586B (en) | Optimize the excavation loading attachment of digging force | |
| CN106759575A (en) | Excavator | |
| CN202706076U (en) | Motion redundant face shovel excavation mechanism capable of reducing hoisting energy consumption | |
| CN210288523U (en) | Excavator suitable for side wall operation | |
| CN103741740A (en) | Excavation mechanism for electrohydraulic hybrid drive mining excavators | |
| CN207700258U (en) | A kind of attachment device and its loading machine for loading machine quick-replaceable equipment | |
| CN215594176U (en) | Crawler type bulldozer | |
| CN115928825A (en) | Working equipment and working machinery | |
| CN202500166U (en) | Tunnel loading machine | |
| CN212104304U (en) | Bucket swinging and bucket door opening and closing control device | |
| CN102720228B (en) | Face shovel spadework device provided with movement redundancy and capable of optimizing spading force | |
| CN202132039U (en) | Excavating device of bucket loading machine for mine roadway | |
| CN201730125U (en) | Bulldozer six-directional shove | |
| CN207436119U (en) | A kind of adjustable-angle ripper dozer | |
| CN209779731U (en) | Excavator arm with freely-converted front shovel and back shovel | |
| CN112796358A (en) | Underground mining prying scraper and mining method thereof |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| RJ01 | Rejection of invention patent application after publication |
Application publication date: 20201204 |
|
| RJ01 | Rejection of invention patent application after publication |